


In using AutoML, the dataset can be explored from the motivated
observation mentioned in the research study. The model-based
features selected is appropriate to the various conditions regarding
transition, approach, and phase environments. g As the target class
will remain to explore the transition (yes and no) search strategy,
this is according to notable performances. The development to
layer datasets with manually predefined objectives were included in
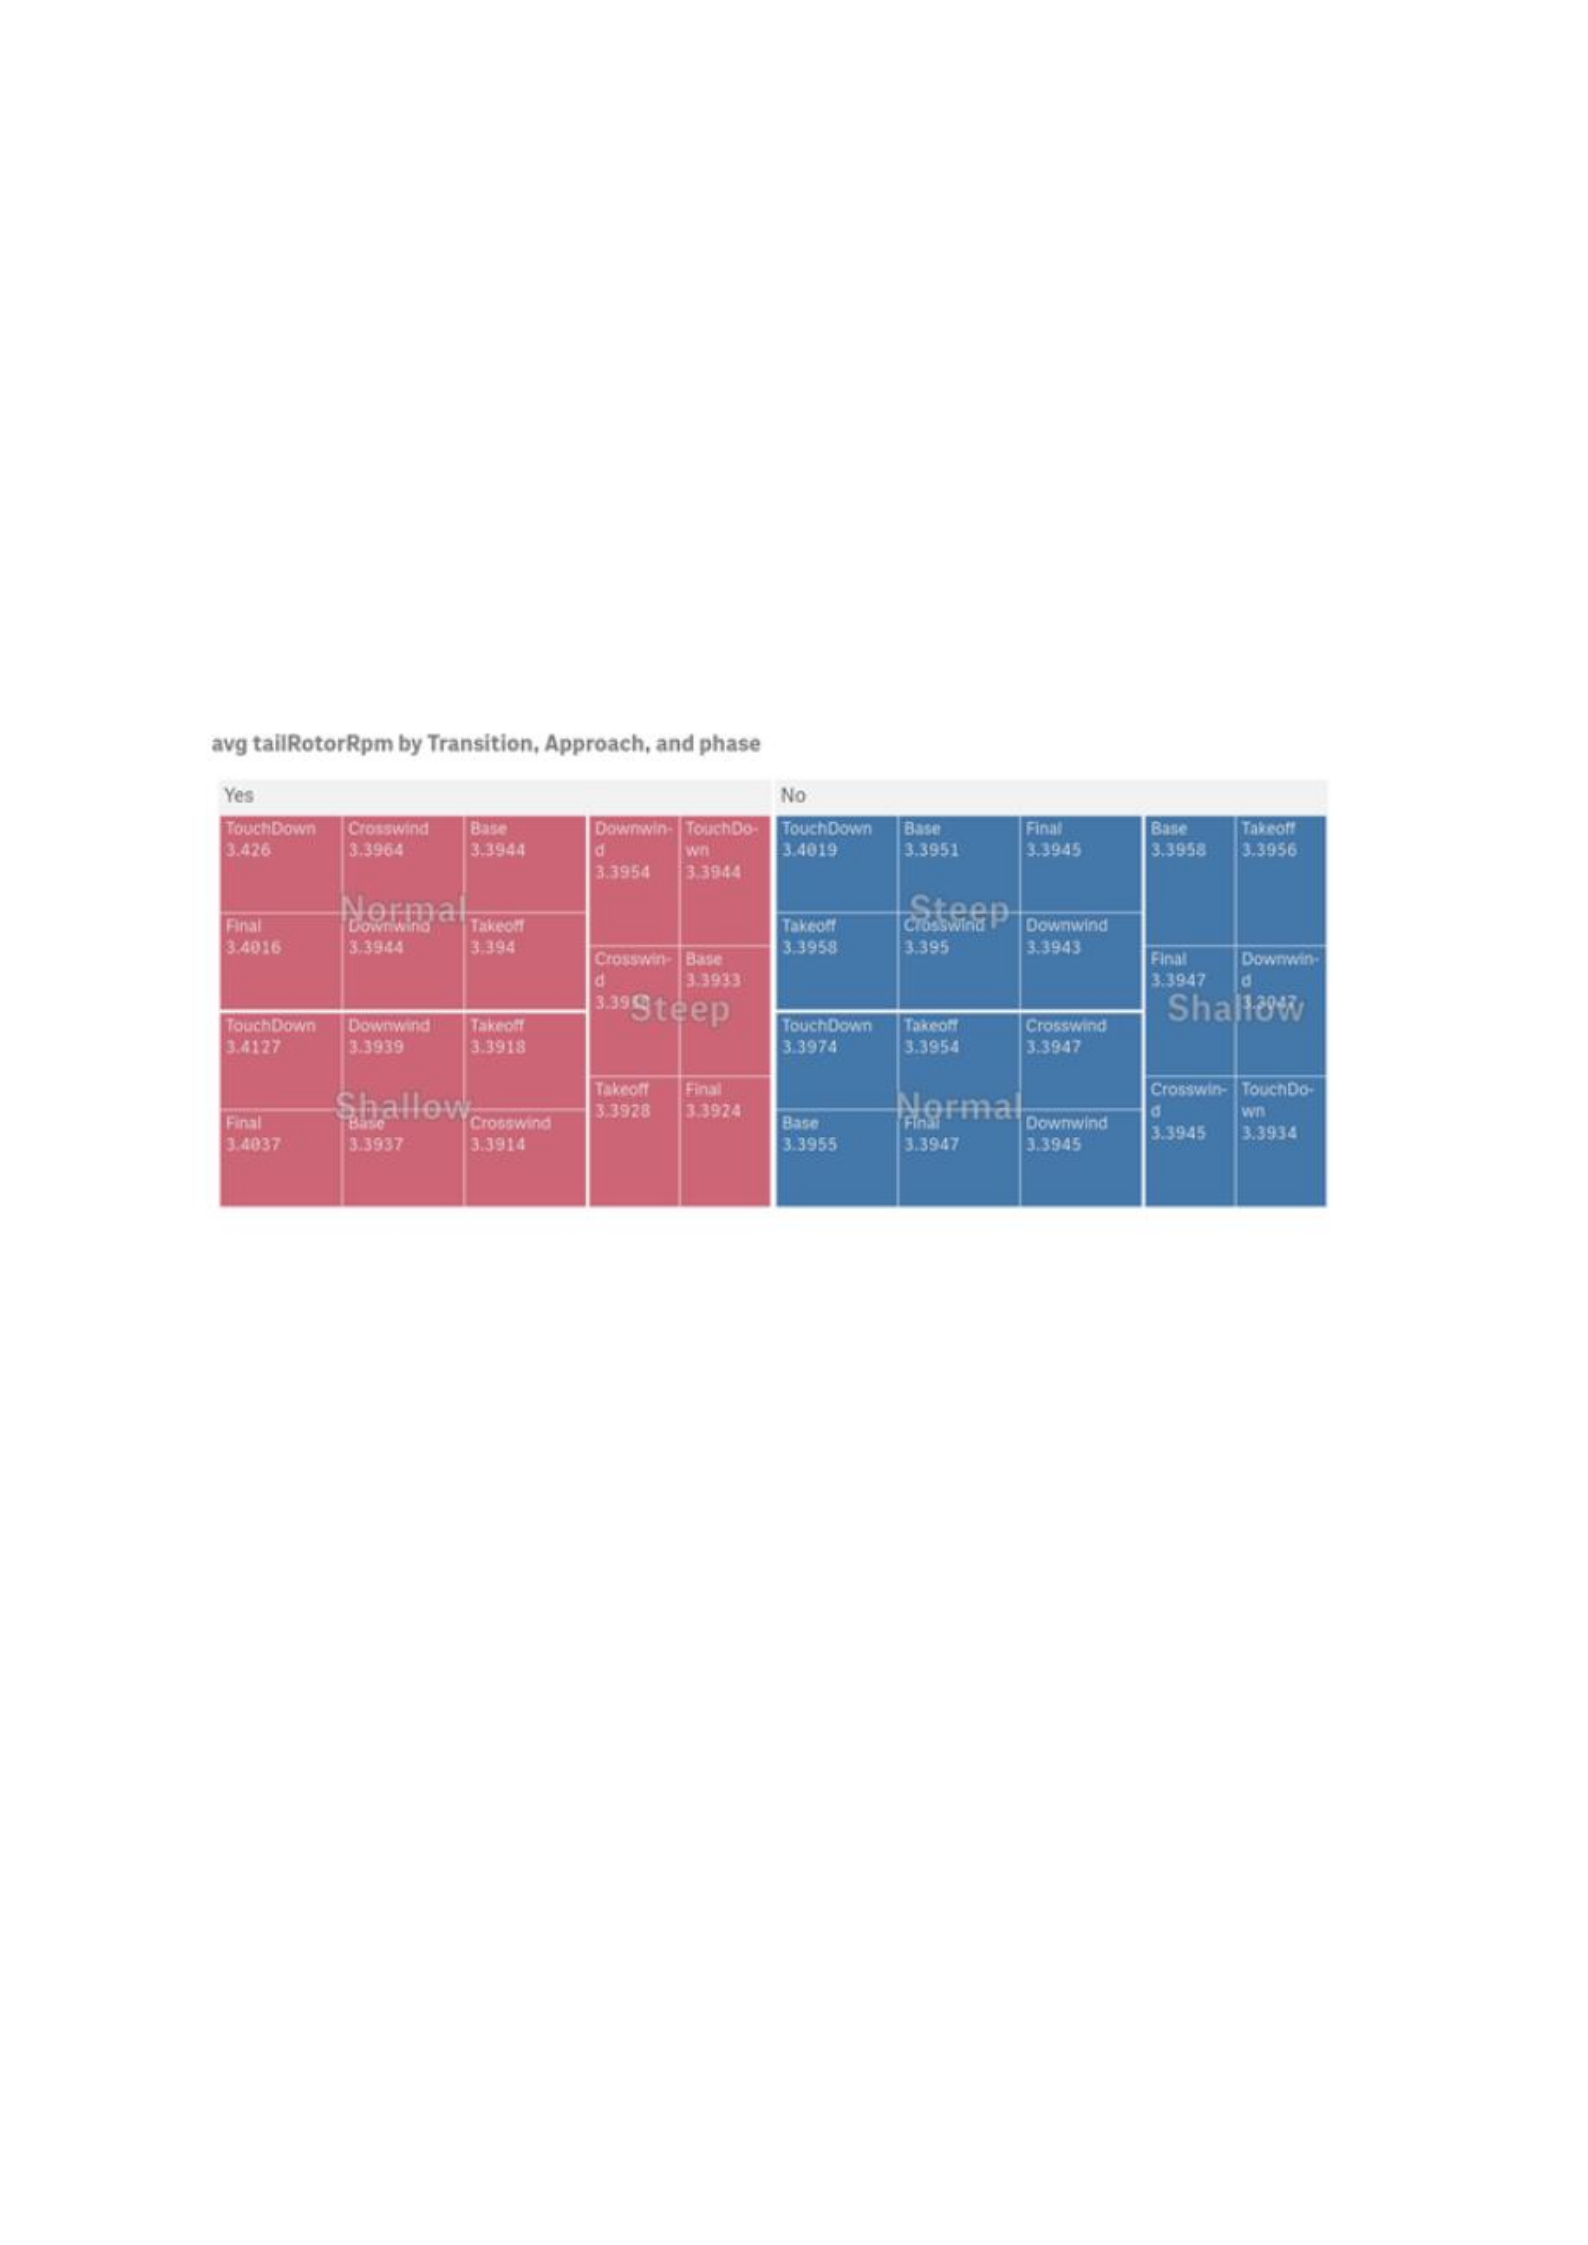
the machine learning algorithms. For example, the average tail rotor
RPM by transition, approach, and phase (see figure below).
Figure
. AutoML Visualization of Average Tail Rotor RPM by
Transition, Approach, and Phase.
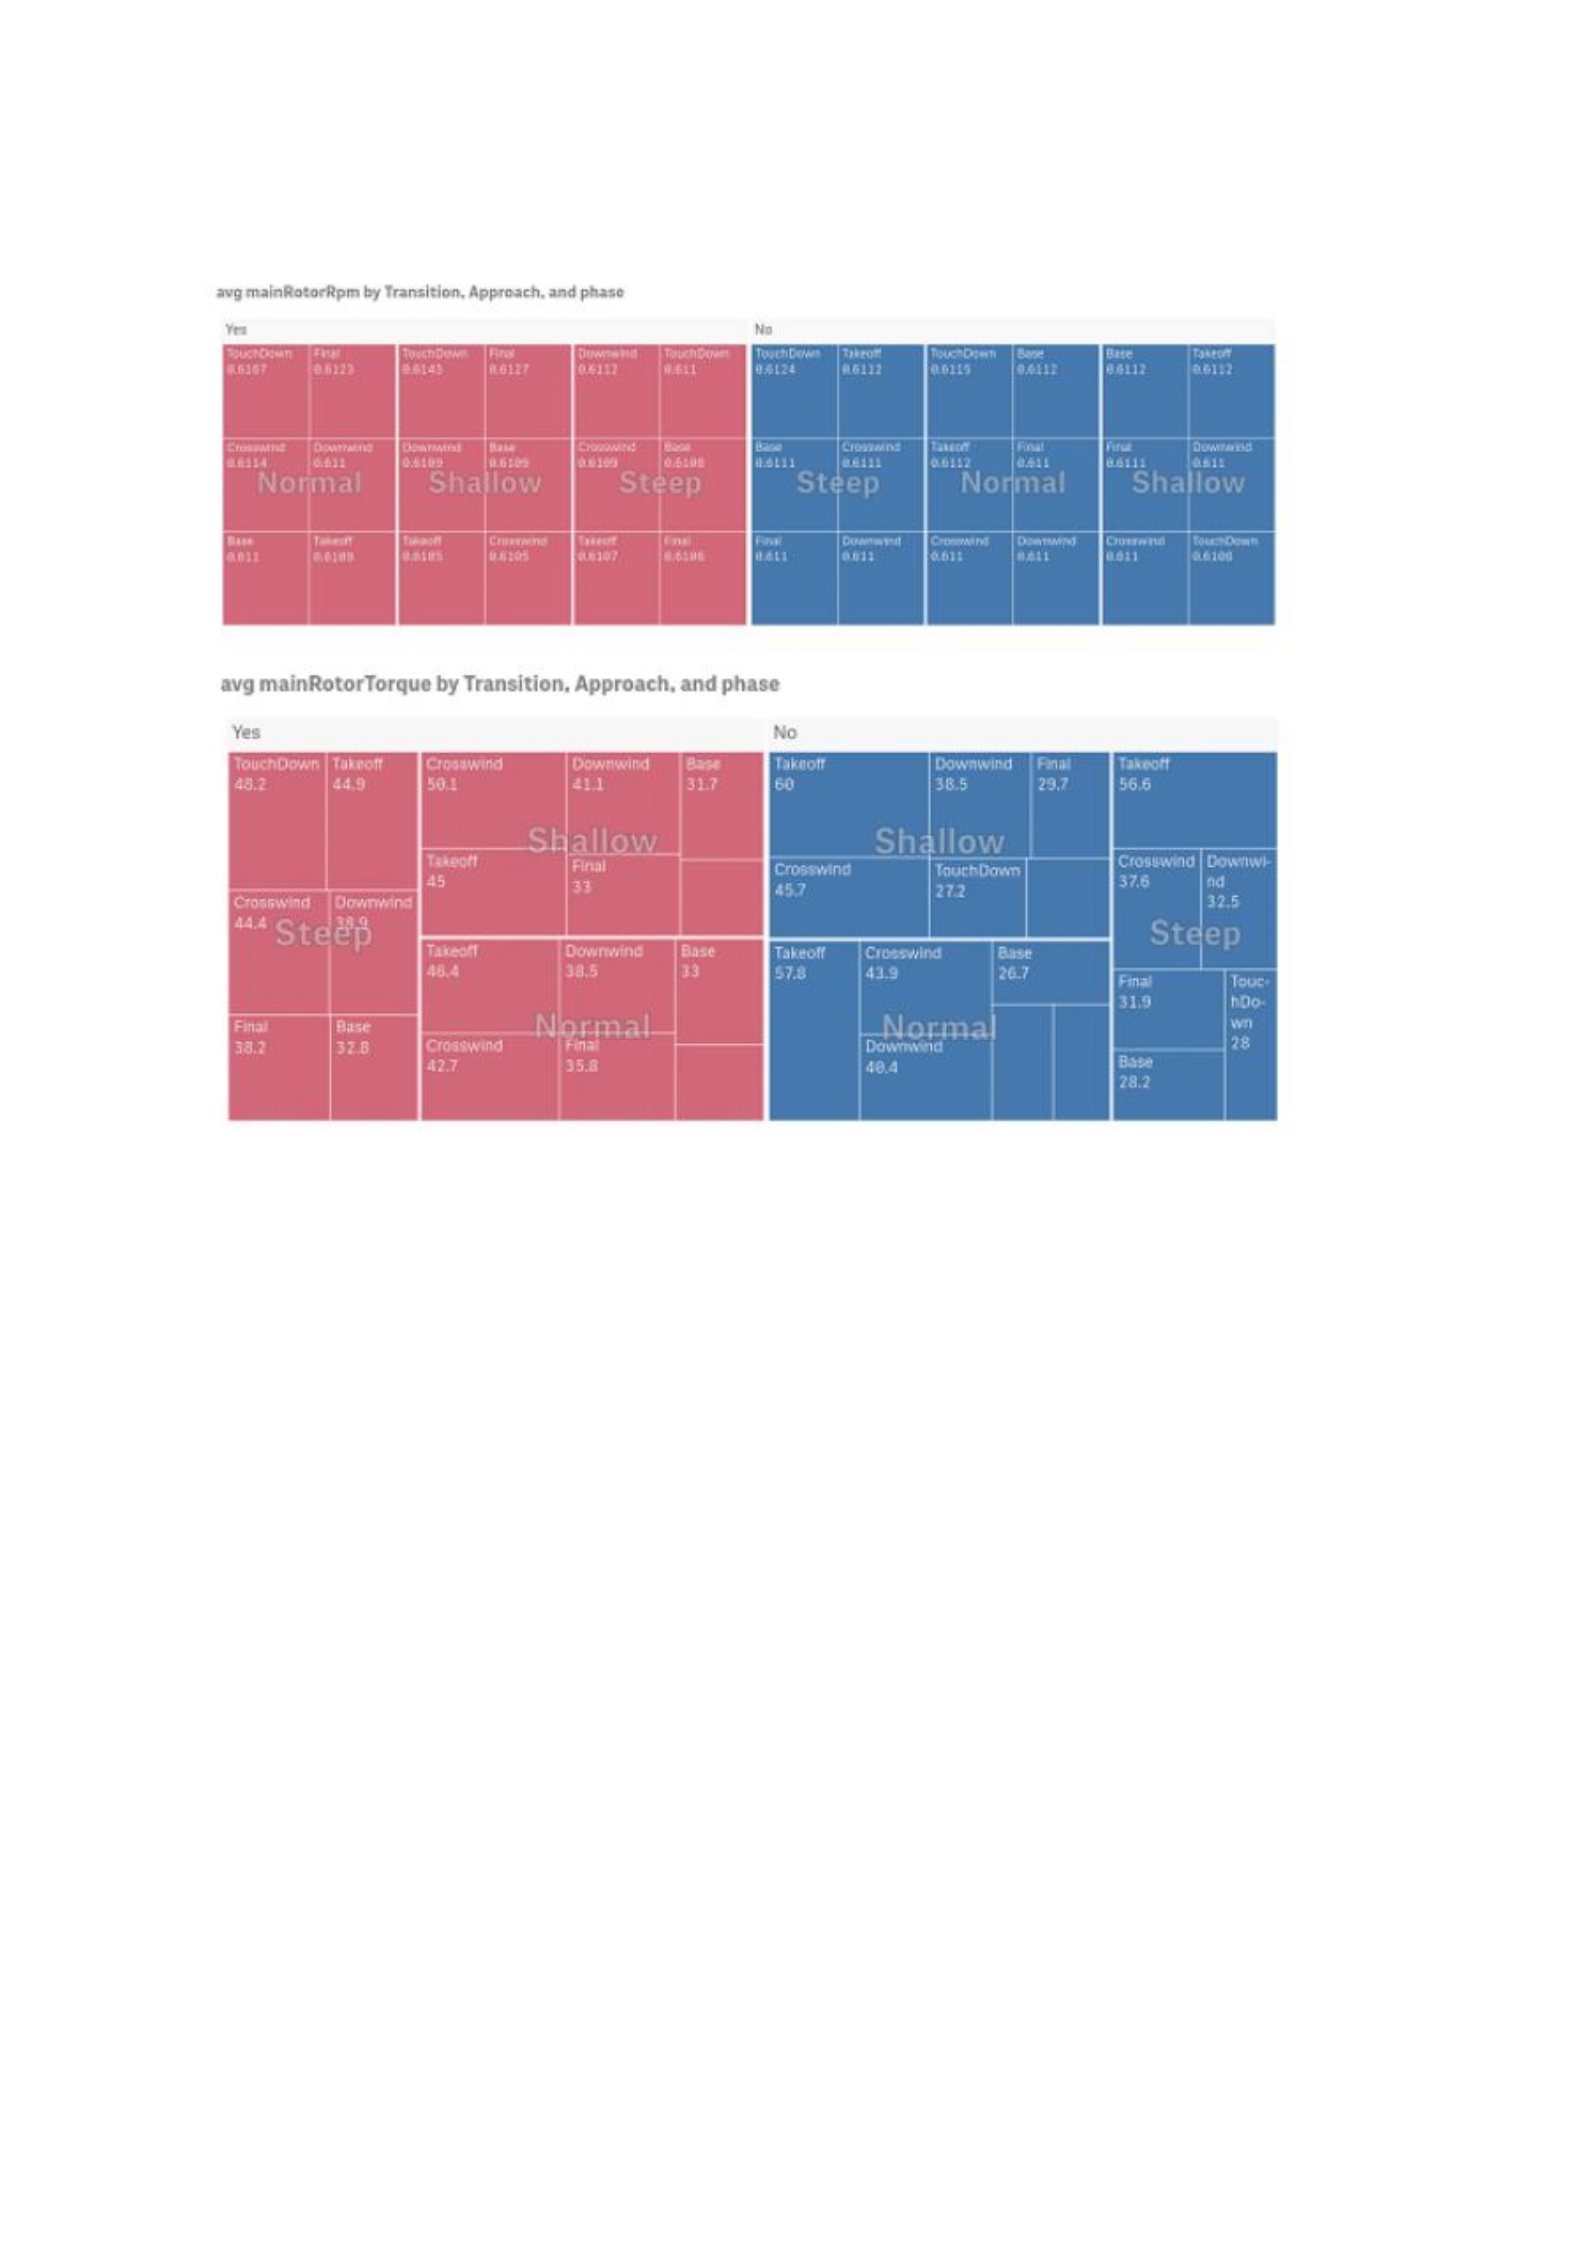
In comparison, the average main rotor RPM versus the average man
rotor torque can also be examined in this study. The examination
consideration all three elements using machine learning to extract
the main rotor conditions in comparison. The parameters to
perform the measures specifically to the traffic pattern
environments allow for the investigation of major contributing
factors and the data mining measures. The data availability to
address the machine learning contributions can be suitable to use as
a methodology to enhance experimental comparisons. The ability to
introduce a experimental benchmark reveals how a domain-focused
AutoML method can explore the various elements aim to enhance
model selection and techniques. The deployed approach of the
AutoML demonstrated the how this practical experimentation can
be model (see figure below).
Figure
. AutoML Visualization with Comparison of Average Main
Rotor RPM and Avg Main Rotor Torque by Transition, Approach,
and Phase.
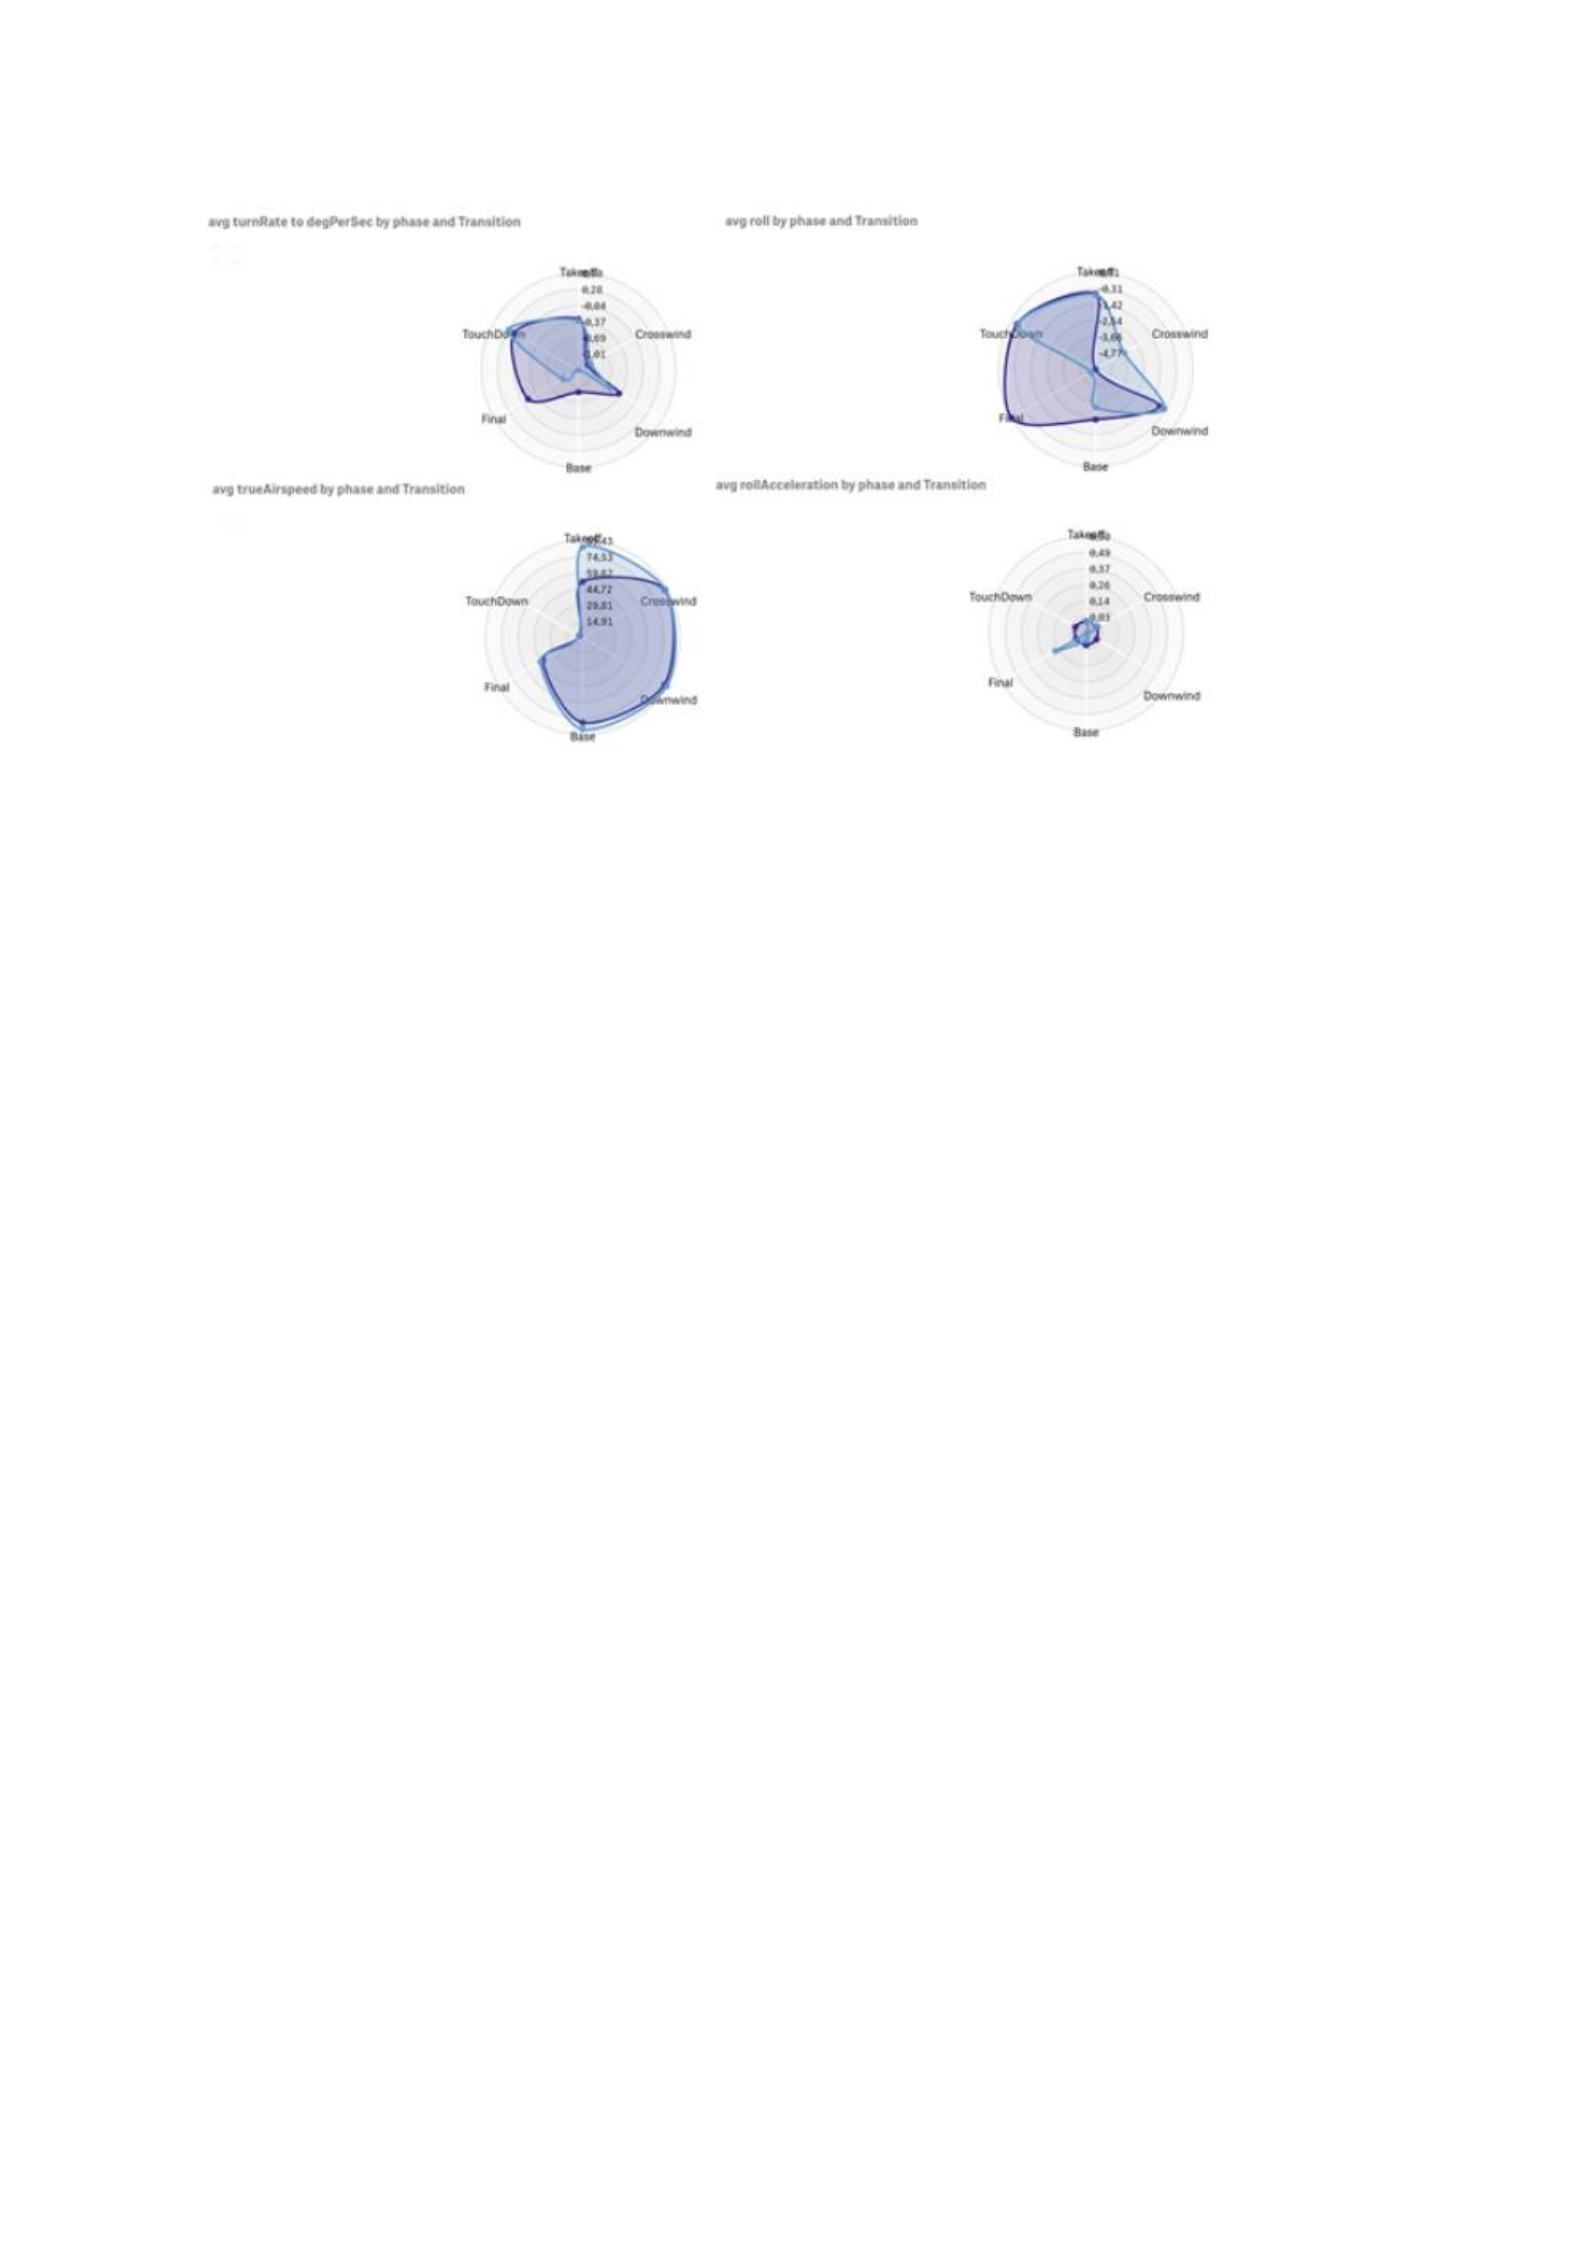
Furthermore, the averages of the turn rate, true airspeed, roll, roll
acceleration by phase and transition includes a
no
(purple) and
yes
(blue) target class. The machine learning methods used to extract
features are achieved a given search according to the algorithm and
the trained designed. The obtained searched was developed to
evaluate the actual performance and the difference between the
proposed outputs. The output probability and the target class of
performance transition has been evaluated according to the number
of experiments in the visualization. The performance varied
between obtained parameters with a solution to optimize
performance and the conditions. The figure below is an evaluation
of the performance conditions associated with each environment.
Figure
. AutoML Visualization with Comparison of Averages – Turn
Rate, Ture Airspeed, Roll, Roll Acceleration by Phase and transition
Main Rotor RPM and Avg Main Rotor Torque by Transition,
Approach, and Phase.
In this evaluation, the ability to explore the attributes as a domain
specific data set has defines the predictability problems for suitable
training. Previously discovered, the new classification of a scheme
associated with the level of autonomy describes the end-to-end
support of the possibilities of AutoML. The understanding of
specific attributes alike creates a demand to improve the efficiency
of machine learning research. Not only the dataset selection
generated pinpointing performances of aspired data, but also the
target class had lay out a roadmap according to association. The
experimental setup was designed to carry-out these methods while
simplifying the modeling process to broadening the application
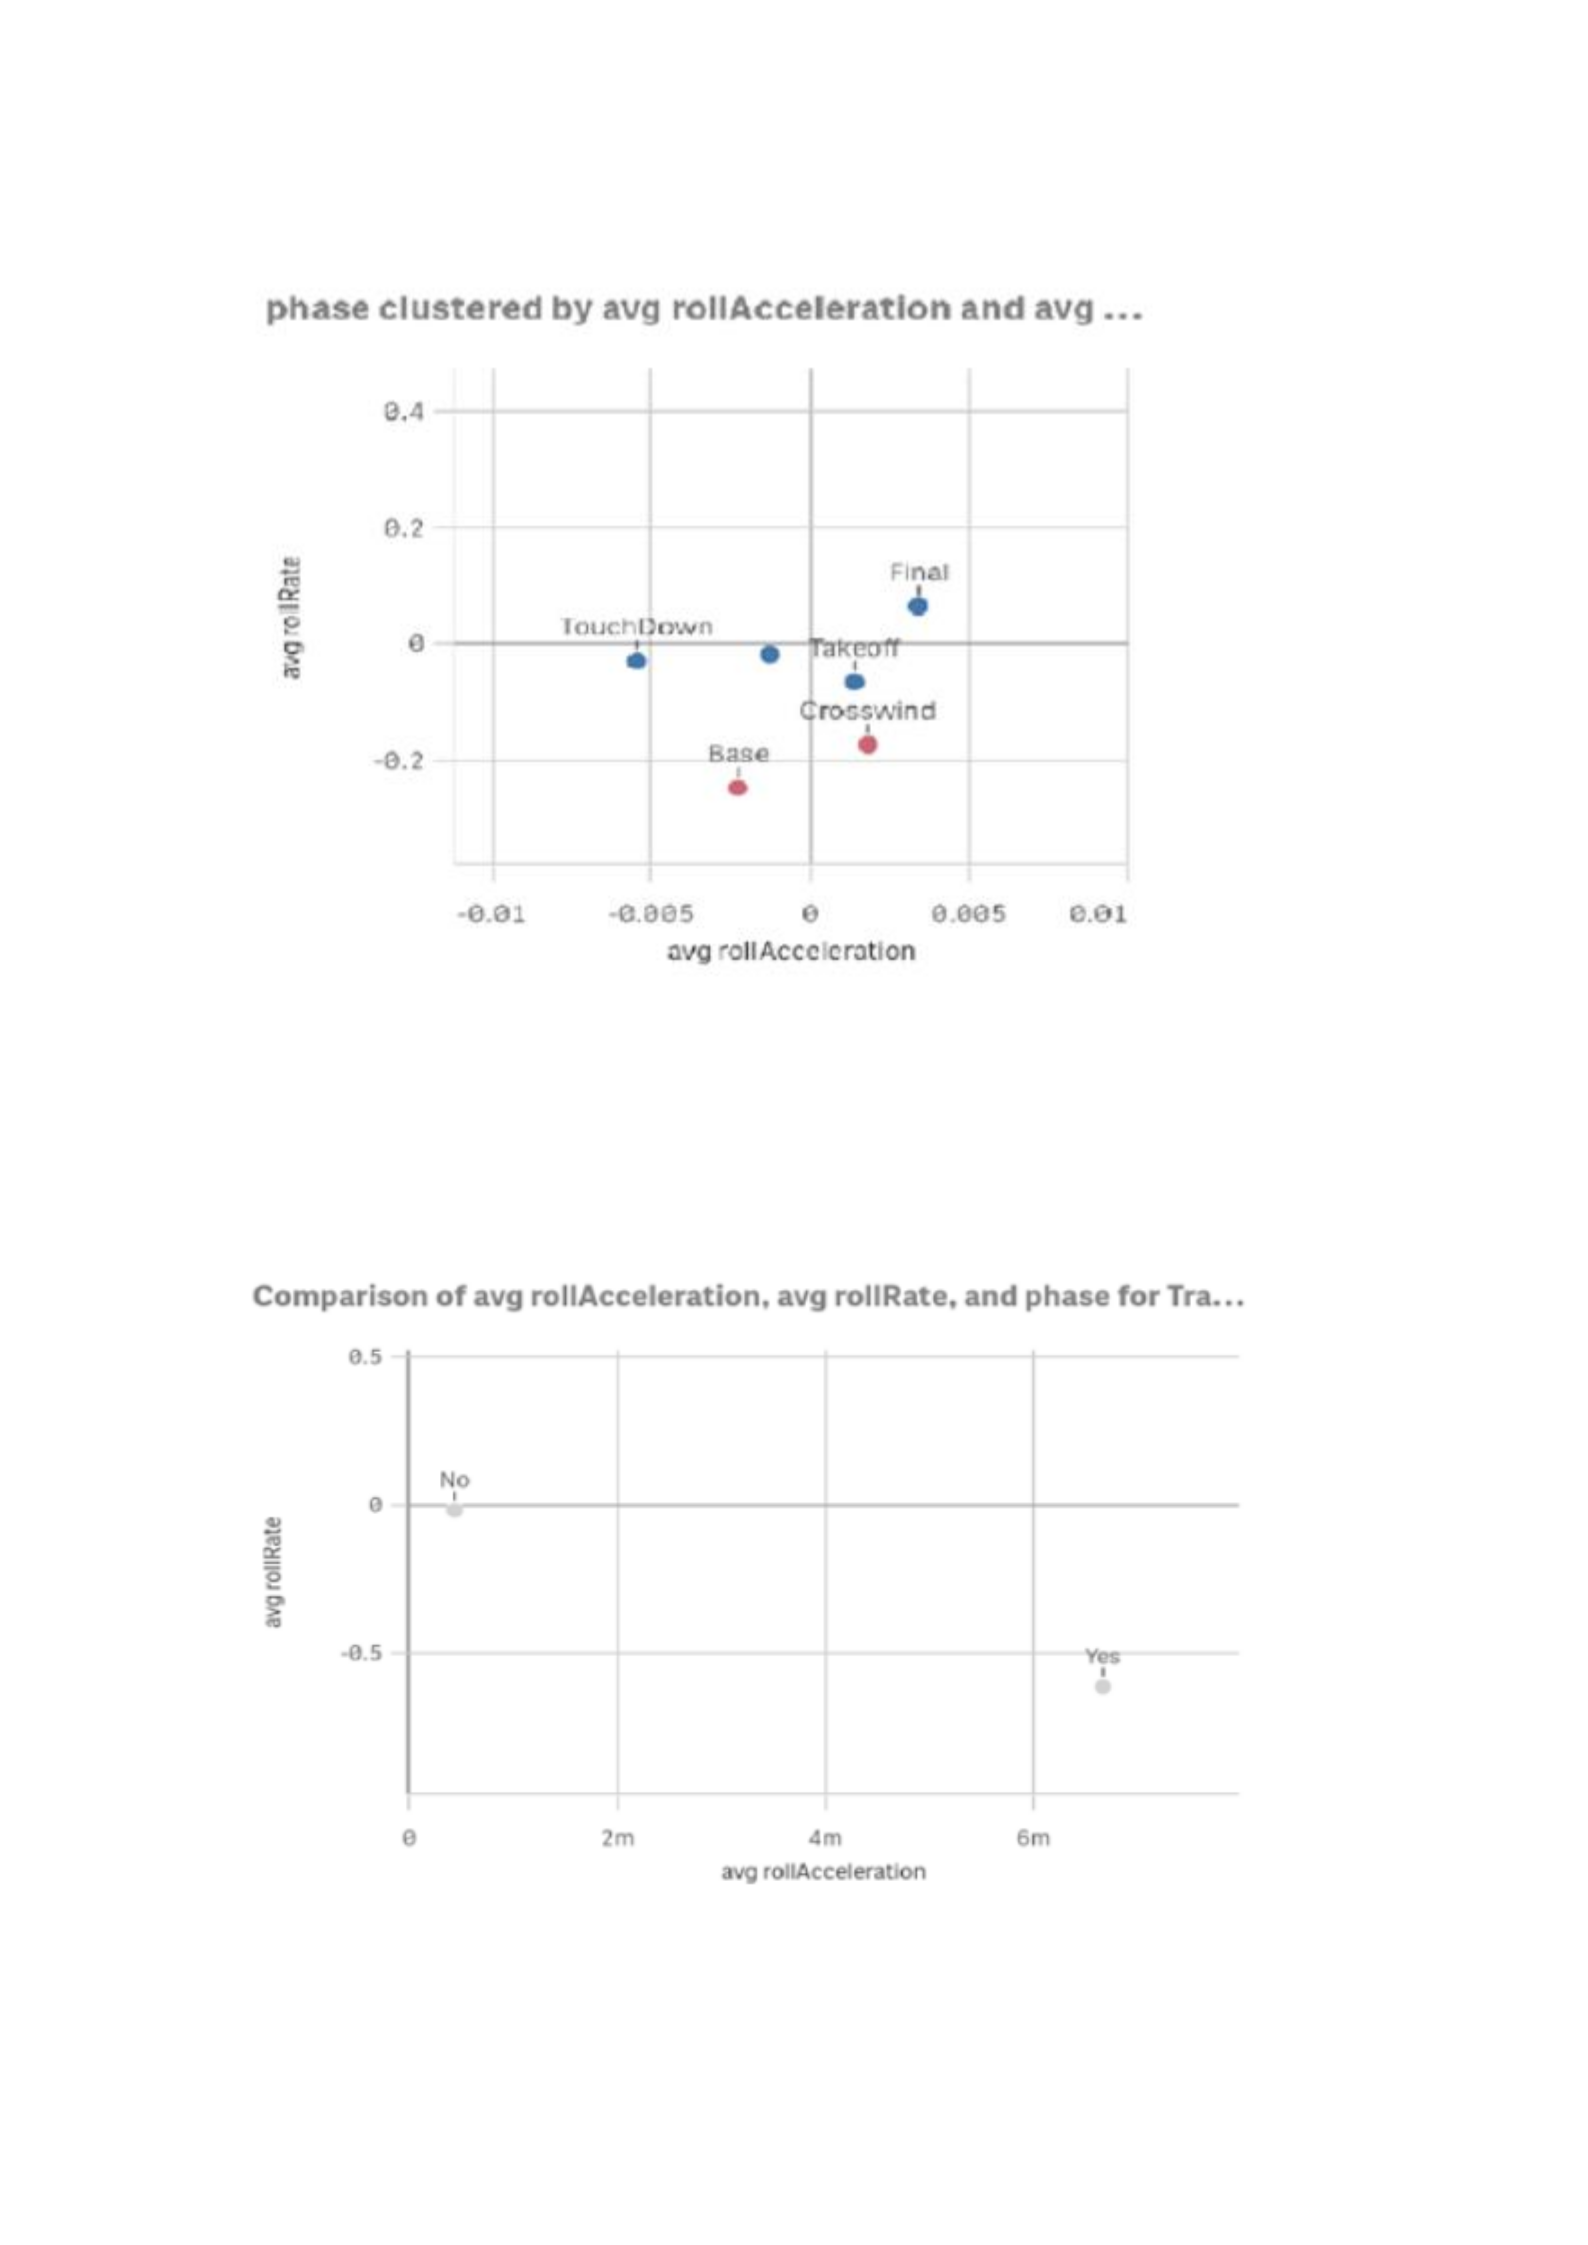
scenarios as original mentioned. The figures below are features
according to the selection based on achievability and combination of
samples using AutoML algorithms.
Figure
. AutoML Visualization with phase clustered according to the
combination of samples.
Figure
. AutoML Visualization with a comparison of the phase
according to the transition segment combination of samples.

