


1
INCORPORATING AND APPLYING
CONCEPTUAL DESIGN TOOLS FOR NAVAL
WARSHIPS
Chapter 1
Introduction
1.1 Conceptual Design of Warships
The task of naval architects, both those directly assigned and those supporting the
U.S. Navy, is to continuously analyze and update conceptual design execution
methods to drive the success of future design projects, reduce costs, and maximize
the performance of ships used by sailors. Architects involved in the design of
warships rely heavily on design tools to help them in the conceptual phase. Some of
the most effective design tools combine knowledge gained from successful previous
designs with the latest research and technology, creating a suite of design tools that
can minimize uncertainty. Currently, graduate students in MIT's Naval Construction
and Engineering program use a variety of design tools such as ASSET/RSDE,
Maxsurf Ultimate, POSSE, and others to support warship design. However, there are
problems with these design tools and their ability to contribute to the progress of the
2N program as a whole, rather than just for individual design projects. One of the
main problems is that some of these tools are outdated, with software no longer
supported by their design teams, making them unsuitable for future use as situational
awareness tools. Furthermore, this problem is exacerbated by the need for all design
tools used by 2N to only access design information that can be released publicly and
accessed by foreign students who do not have a U.S. security clearance. These

2
problems have created gaps in the design tools available to 2N students, and to
address these problems, a new thesis project was developed to implement a new
package of design tools that are not classified for 2N, with the aim of improving the
quality and efficiency of conceptual ship design.
During this thesis project, the search for a new design tool was carried out and
successfully completed. A powerful new platform for conceptual design tools was
identified, adapted for 2N use, and built on top of it. In addition, a new module for
the automatic manufacture of critical engineering components in Rhinoceros 7 using
the Grasshopper plug-in and Orca3d was created. This module assists the design
team with the structuring of vital engineering equipment across the ship's three-
dimensional model, helps assess the feasibility of the design, as well as examines
potential equipment interference within compartment areas and volumetric
constraints. As a demonstration of this design tool and the effectiveness of the new
initial setup tool, a case study of a medium-sized surface combatant ship is included
in this paper.
1.2
2N Design Project 2,705
MIT's Naval Construction and Engineering Program (2N) features a 2.70X series of
naval architecture courses built toward a year-long capstone course (2,705) with the
goal of producing conceptual warship designs. The general design pursued by the
students included many forms of modern monohull surface combatants, although
advanced marine vehicles such as multi-hulls, planing ships, submarines, and
autonomous vehicles were also chosen with great success. In this thesis, the design of
the monohull surface combatant is the main focus and the tools researched and
implemented are also the best performing for the conceptual design of the monohull.
1.3 Design Tools Currently Used by 2N
Many naval architectural design tools in the form of software packages are available

3
for use in academic settings that can help with conceptual design. Now
The most
commonly used design software in the 2N program is the Advanced Ship and
Submarine Evaluation Tool (ASSET). ASSET is a government-sponsored ship
synthesis package that uses a robust parametric design process offset by
The characteristics of U.S. Navy ships quickly converged on effective ship design.
This tool is particularly useful for designing more traditional monohull warships,
although multi-hull designs and other more advanced marine vehicles are possible
but their effectiveness is limited. 2N students in the past have created their own
design tools to support the design of smaller ships or advanced marine vehicles in
situations when ASSET was deemed ineffective for a variety of reasons. In 2010,
Gillespy found that ASSET was unable to adequately capture and evaluate the design
space for patrol vessels, and created its own design tool to evaluate the marine
maintenance performance of patrol vessels [2]. Als o i n 2 010, K a ra u sed t h e
A SSE T data base ext e nsi vely f o r p a r ame t ric co m p ar i s ons o f s hip
c omp o ne n t s suc h as wei g ht a nd size . [3] He also created a new design tool
for evaluating corvette-sized ships and his work showed the power of having direct
access to accurate databases of known ship systems.
ASSET software is no longer supported by the U.S. Navy, as a Rapid Ship
Design Environment (RDSE) is available that leverages the Leading Edge
Architecture for Prototyping Systems (LEAPS) database to support and create
efficient design architectures. The Formal Object Classification for Understanding
Ships (FOCUS) is a large database of known surface ship data, and is used by
ASSET and RSDE to quickly invoke known parameters to converge on a good hull
design using ship synthesis. [4]. O ne of the main advant ages of LEAP S is
tha t it allows mu lt ipl e de sign tools to c all simil ar da tabases f or
informati on, which inc rea ses eff icie ncy by a llo wing fo r e asie r
int egration of tool s. Fu rthe r design tool s such a s Sm art Sh ip Sys te m
De sign (S3 D) ar e al so bein g deve loped and util ize the LEAPS
database an d wou ld be advantageous to p oten tially incorpo rate i nto
concept ual design pa rts where a more d eta iled initial desig n would
be pos sib le [4]. Further complicating the issue is that no publicly

4
released version of the RSDE is currently available, although some
interest has been shown by engineers at the Carderock Naval Surface
Warfare Center potentially developing this in the future. Therefore, the
potential
Fully integrating RSDE/LEAPS as the primary 2N design tool is avoided
although the use of edited and case-specific RSDE/LEAPS as the primary design tool
is still possible for U.S. Navy 2N students. Although the ASSET and RSDE analyses
do not provide a clear path forward, they demonstrate the power of the ship synthesis
tool and some advantages of using a trusted and robust database of hull parameters
and ship systems that are known and serve as examples of the capabilities that this
new design tool should bring to the 2N program.

5
Article 2
Virginia Tech's Navy Concept and
Requirements (C&RE) Tools
2.1
Current Research
Currently at Virginia Tech (VT), a team of researchers under the guidance of former
2N Academic officer and NAVSEA Ship Design Professor Dr. Alan Brown is in the
process
of updating the Naval Concepts and Requirements Exploration (C&RE)
design tool that represents more than two decades of research and development [5].
T h e n e w C & R E d e s i g n t o o l w a s c r e a t e d b y a t e a m o f n a v a l
a r c h i t e c t s a n d s u p p o r t e d b y r e s e a r c h c o n d u c t e d a t M I T a n d
V T t o p r o v i d e a p o w e r f u l t o t a l s h i p c o n c e p t u a l d e s i g n t o o l
f o r w a r s h i p s , c o n v e n t i o n a l s h i p s , a n d o t h e r m o r e a d v a n c e d
m a r i n e v e h i c l e s . T h i s t o o l a n d i t s s u p p o r t i n g d a t a a r e
s u i t a b l e f o r p u b l i c r e l e a s e a n d a r e c a p a b l e o f s u p p o r t i n g
n a v a l a r c h i t e c t u r a l d e s i g n p r o j e c t s f o r d e s i g n e r s w i t h a n d
w i t h o u t e x p e r i e n c e o n n a v a l w a r s h i p s . M o r e t h a n 2 0 y e a r s
a g o , B r o w n w a s p r e s s u r e d w i t h t h e n e e d t o d e v e l o p n e w a n d
u n c l a s s i f i e d d e s i g n t o o l s f o r u s e i n a c a d e m i c s e t t i n g s . I n a
2 0 2 2 a r t i c l e f e a t u r e d i n t h e N a v a l E n g i n e e r s J o u r n a l , B r o w n
d e s c r i b e d t h e c u r r e n t s t a t e o f C & R E t o o l r e s e a r c h a s " P r i o r
t o 2 0 0 2 , t h e o r i g i n a l A S S E T h a d n o t b e e n c l a s s i f i e d a s a D
D i s t r o a n d w a s u s e d i n V T a n d M I T p r o g r a m s , b u t
s u b s e q u e n t l y , i t b e c a m e c l e a r t h a t t h e u s e o f A S S E T / L E A P S
f o r g e n e r a l g r a d u a t e a n d u n d e r g r a d u a t e c l a s s e s a n d p r o j e c t s
n e e d e d t o b e d i s c o n t i n u e d a n d a t V i r g i n i a T e c h w e w e r e

6
g r a d u a l l y e x i t i n g A S S E T .
curriculum and replace it with our own Concept and Requirements Exploration
(C&RE) tool... These tools have been continuously developed and improved over the
past 15 years supporting research and design under several ONR grants, NAVSEA
funding and the Naval Engineering Education Consortium (NEEC) "[1]. T his
d esc r ip t i on c orr ela t es c l o sely with t h e c urr ent c hal l enge s w i th t he
d esi g n t o ols t hat the 2 N p rog r a m i s t ryin g t o s o l ve, e s pe c i ally t he
n eed t o r emove a nd r e p lac e A S SET a s t h e m ain d e sig n t o o l a n d
c ond u ct a ll f urth er r es e a rch at a n u n cla s sifi e d l e vel.
C&RE's suite of design tools was heavily influenced by ASSET during its
creation as its founders were trained at ASSET at MIT and through other avenues of
naval service and research. Many of the research team members are also 2N
graduates which greatly increases the likelihood of successful collaboration between
VT and 2N on future projects. The weaknesses and limitations of ASSET in an
academic environment were well understood and improved during the creation of
C&RE tools and eliminated many of the frustrations that design teams face today
when using ASSET as a primary design tool. Naval architects using C&RE have
more control over the total ship design process including utilizing proven processes
to create and compliment design spaces that are then fully integrated into the
synthesis model. This is very much in line with the current syllabus of the 2.702 and
2.703 2N courses, and creates an opportunity for a more uniform process for creating
and exploring design spaces for new naval vessels. The high level of automation in
ASSET severely limits the designer's ability to fully understand the decisions made
when a button is selected or a parameter is selected. C&RE gives this control back to
the design team with reduced automation.
After much coordination between the leadership of the MIT 2N and VT naval
architecture programs, the decision was made to pursue the implementation of the
C&RE tool package for use by 2N in the hope that the continued collaboration
between the two naval architecture programs will continue to make the C&RE tool
the primary unclassified design tool for naval warships and will be used for many
years to come. This decision was further supported by naval leadership in NAVSEA,

7
the Office of Naval Research (ONR), the NAVSEA Carderock division, and the
Naval Surface Warfare
The Dahlgren Center increases the support and future growth
potential that the C&RE tool package can experience through implementation in the
2N program.
2.2
C&RE Tool Design Process
The C&RE design process is characterized by two important phases of design:
Concept Exploration and Concept Development. Throughout this phase the
important steps of this process can be further characterized as the creation of Logical
Architecture, Physical Architecture, and Operational Architecture. Through this
phase, the total ship system is designed and incorporated into the synthesis model. A
three-dimensional hull model was developed, designed, and evaluated using a total
ship synthesis approach with embedded feasibility analysis, Overall Measure of
Effectiveness (OMOE) analysis, and overall measure of risk (OMOR) analysis.
There are two common ways to approach total ship synthesis, namely the "inside-
out" or "outside-in" method. "Inside out" refers to a strategy in which the design of
the ship's systems and subsystems is completed first, followed by the synthesis of
designing a hull capable of supporting all of these ship's systems. The "inside and
out" method refers to the completion of the hull design first, and the ship's systems
and subsystems are built within the limitations of the hull through synthesis. Both of
these methods have proven to be successful. Brown describes the C&RE approach to
ship design as an "outside-in" approach, meaning that the ship's systems are designed
in parallel with the hull design and synthesis combines these processes to converge
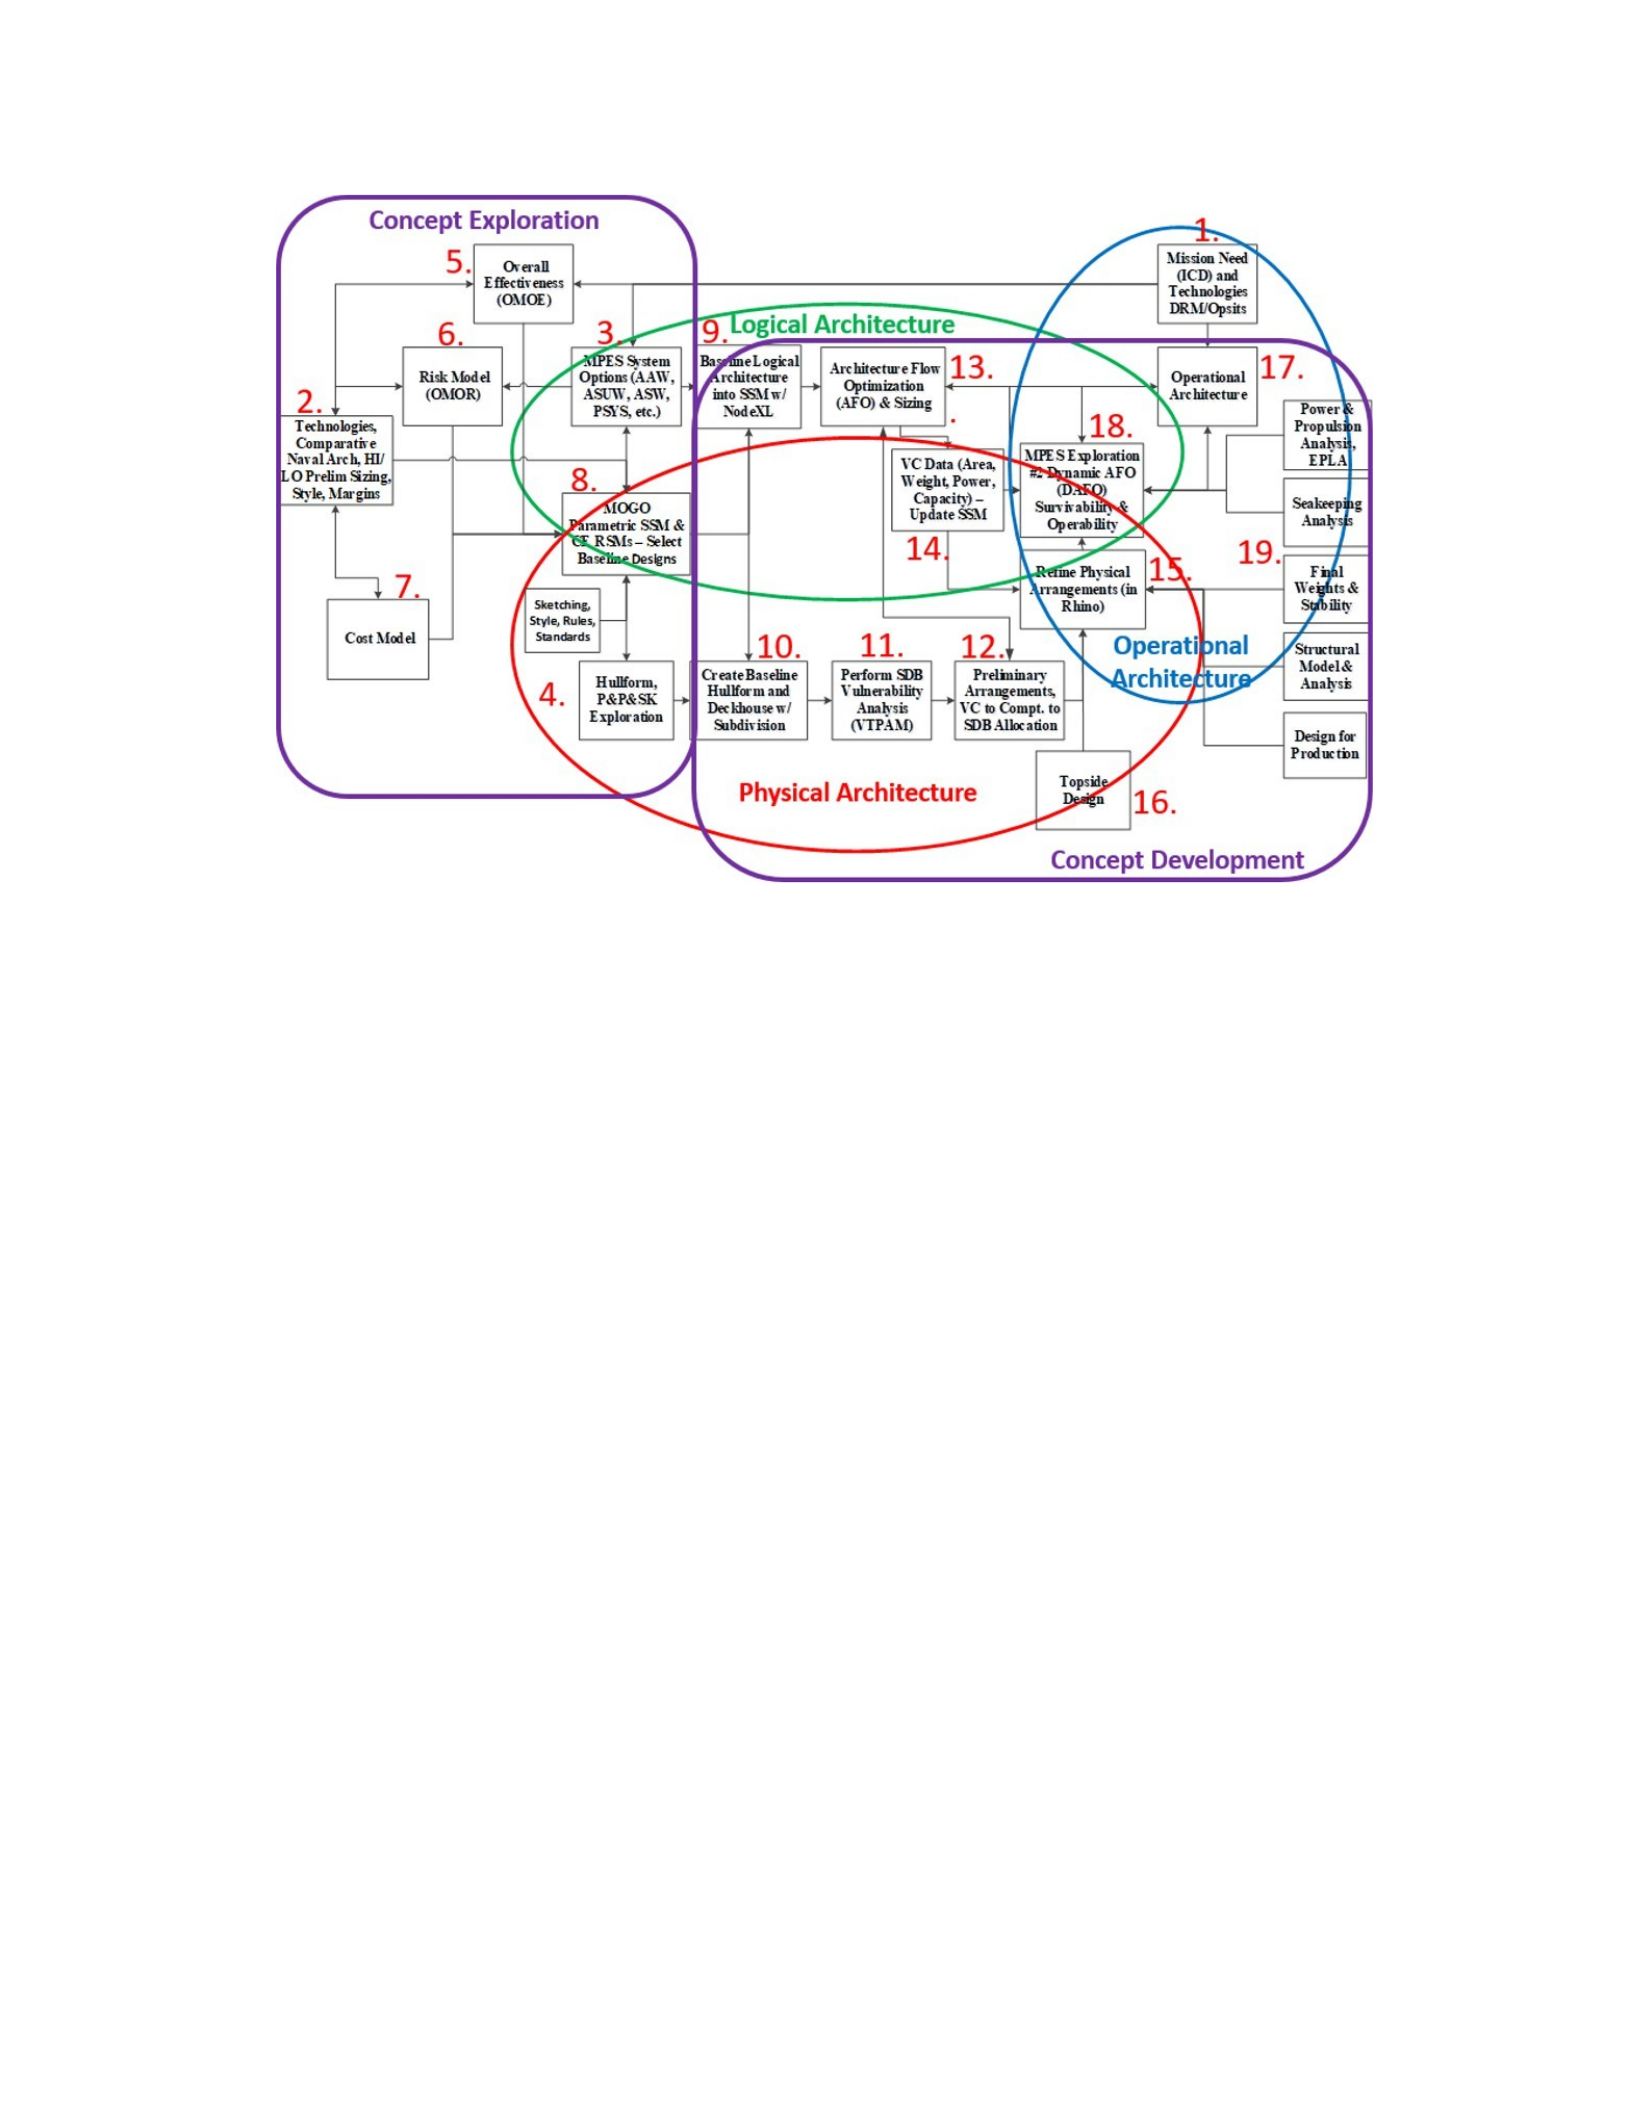
on an acceptable outcome [5]. The 2-1 below represents the 19 steps of the C&RE
process. The remainder of this chapter will summarize the high points of this process
with a greater emphasis on concept exploration (steps 1-8) and how this process
applies to the design of warships in the 2N program.
The following flowchart represents the 19 steps of the C&RE Design process.
8
Figure 2-1: C&RE VT Design Process [1]
Steps 1-8 in figure 2-1 shown above represent an exploration of the concept. An
initial capability document (ICD) is the first step of the process and this document is
created by the design team, usually after reviewing the project sponsorship
requirements while also including the child requirements. The creation of the ICD
was the first step in the 2,705 design project. For some naval officers, such as
experienced submarines now designing surface ships, or the opposite situation,
further research into the capabilities of the current U.S. Navy or foreign platforms
will be necessary to accurately create an ICD. Creating a Concept of Operations
(CONOPS) document can help the design team to visualize the operational mission
that must be completed, and refine the requirements in the ICD.
Throughout the Concept Development, comparative naval architecture and
parameter size calculations are carried out to create a first look at the potential design
space. Also during this phase, it is important to consider the additional systems that
may be installed, the associated sizes, and how these systems will be able to achieve
the requirements and objectives outlined in the ICD, CONOPS, and
9
also other requirements that have been set by the design team's industry sponsor. The
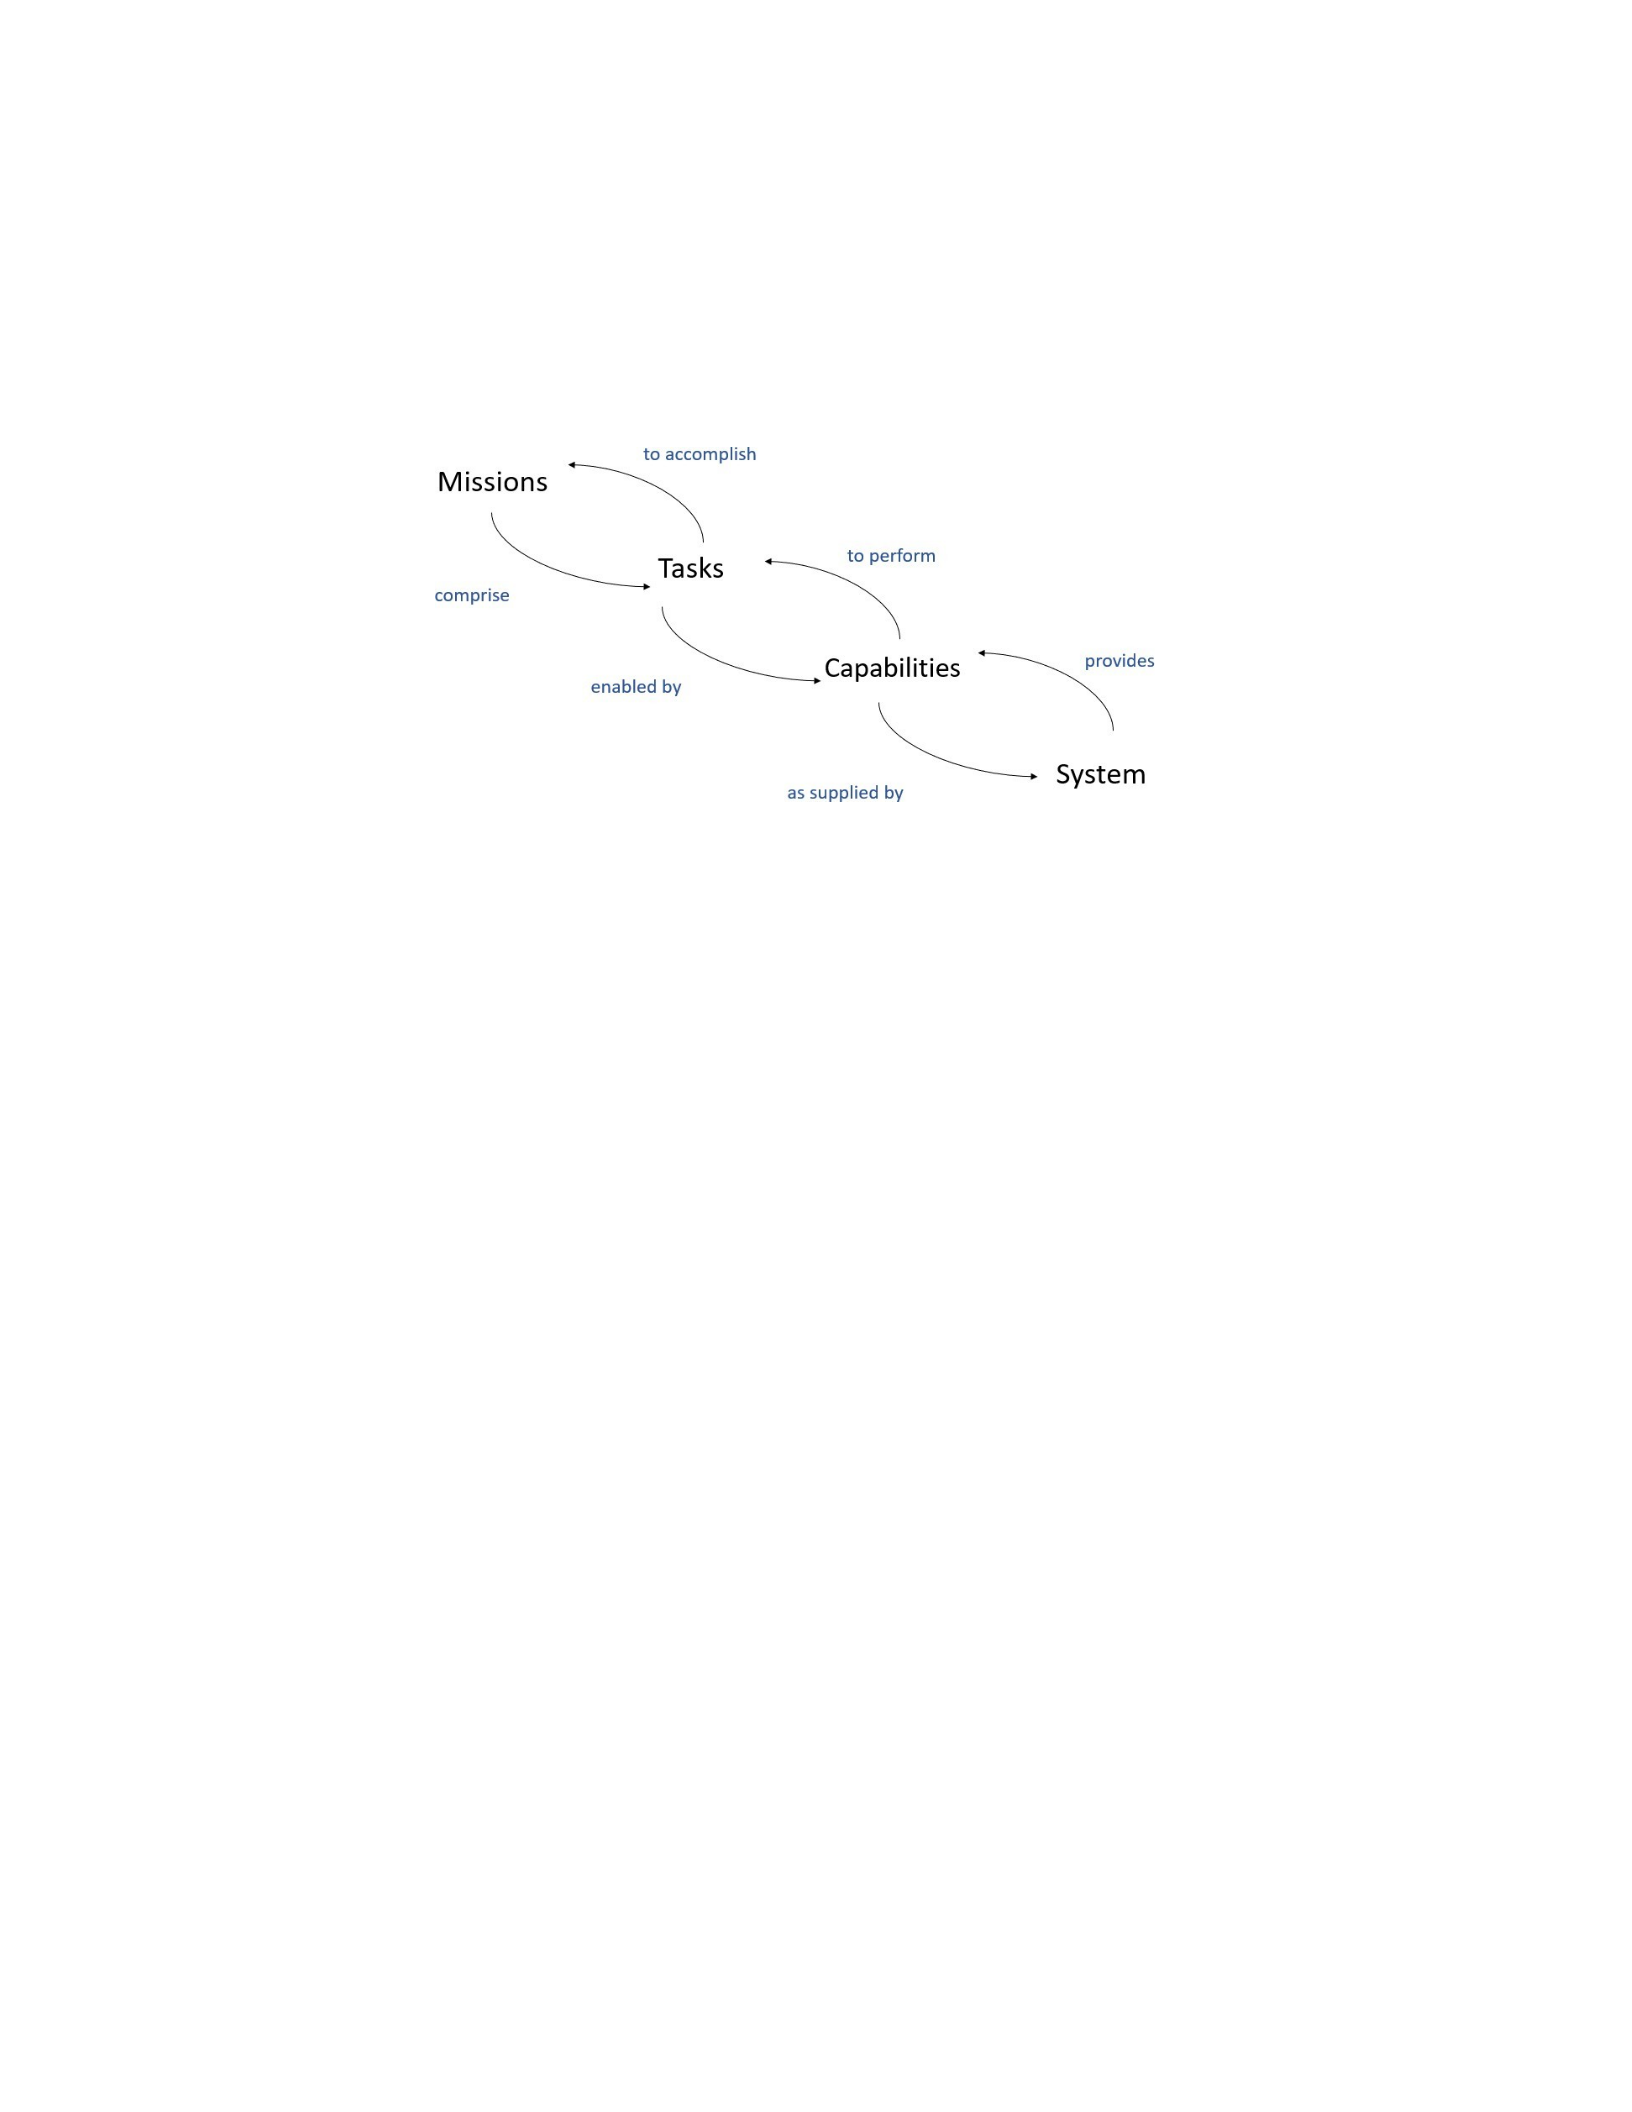
relationship between the ship's system and mission achievement is simple and is
marked by figure 2-2 below.
Figure 2-2: Ship Systems for Mission Achievement [1]
Navy officers in the 2N program generally have a strong understanding of how
ship systems interact and the fact that many different architectures and system
components can achieve the same mission objectives. This is why parametric sizing
and outside research can be very helpful during this design phase to understand the
variance in size, weight, and power requirements for different combinations of
systems. Typically, the system hierarchy is set and the best-performing system can be
considered a "wish list" for the design team. This may include new cutting-edge
naval systems that are still under research and development that are expected to work
at a high level. Integrating this system into design at the academic level is very
common. Incorporating new technologies can be a difficulty using a program like
ASSET, but the process is very easy using C&RE tools. This gives 2N students the
ability to pursue nontraditional design projects that may have had too much
uncertainty in the past, or there is no clear way to complete design validation or
verification definitively beyond careful calculations for weight and power
requirements. This type of design decision-making is accommodated during step #3,
Mechanical Power and Energy System (MPES) design.
10
This initial system design was incorporated into a model of the ship's synthesis later
in the process to help explore the design space. After completing the ICD, initial size
calculations, and related comparative naval architecture designers can now move
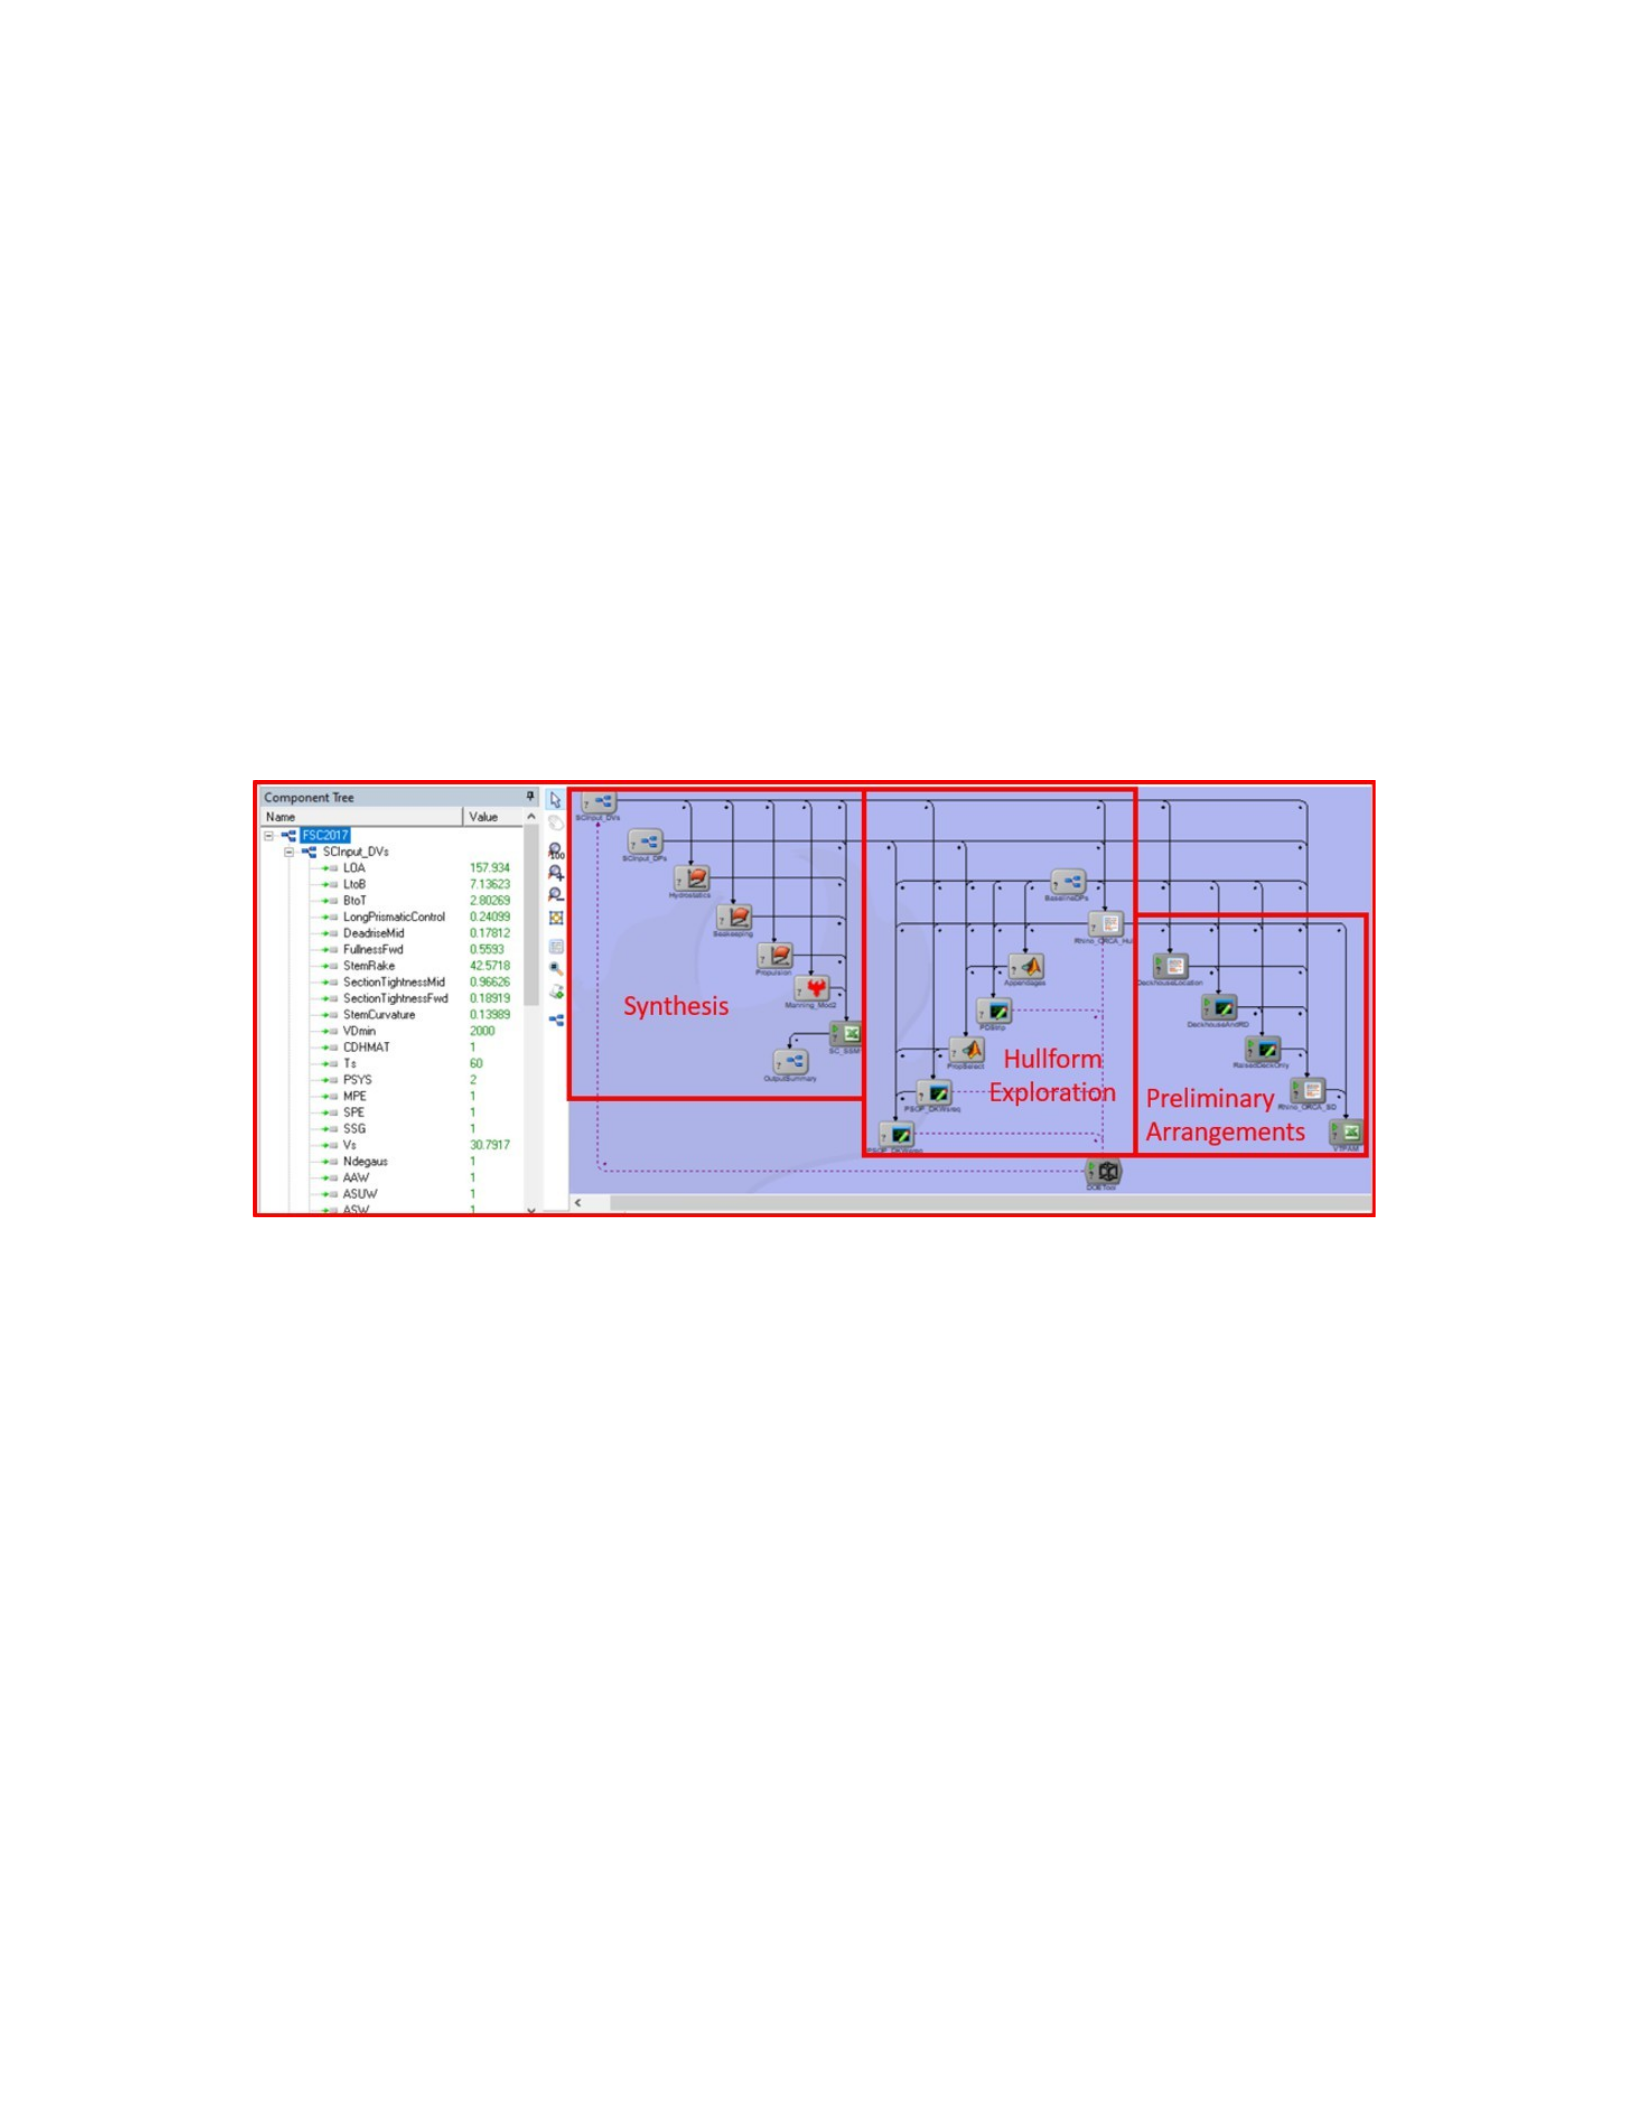
their work to the Model Center to continue the C&RE process. Figure 2-3 below
shows an overview of the Model Center workspace, and the separation of modules
based on synthesis, hull exploration, and initial setup. The left side (synthesis) of the
Model Center workspace is described as Concept Exploration, while the right side
(Hullform Exploration/Initial Settings) is named Concept Development [1]. To
ach iev e t otal shi p syn thes is, each mo dule mu st be co mp leted by t he
desig ner.
Figure 2-3: C&RE process in the Cen Modelter[1]
In its basic configuration, the VT Ship Synthesis Model (SSM) represents the
MPES of a medium-sized surface combatant and represents a new design for a U.S.
Navy frigate or similar-sized vessel. This information represents an excellent
baseline when starting a design and can be easily scaled to represent surface
combatants of various sizes or hull shapes. Inside the synthesis model there are
separate Excel worksheets for Design Variables (DV) and Design Parameters (DP),
combat systems, mechanical systems, propulsion systems (PSYS), electricity,
Overall Effectiveness Measures (OMOE), Overall Risk Measures (OMOR), and
others. This worksheet can be modified by the design team to more accurately
represent the design capabilities intended for the purpose of incorporating all known

11
critical engineering and combat systems
into the synthesis model. By completing this
step, the design team can feel confident moving forward that the output of the
process will result in a design that is capable of fielding all of the ship's systems of
interest and can meet the project's performance objectives. The SSM can also be
modified to incorporate all Combat systems for the ship's design. Combat system
information is entered into a separate Excel worksheet for each area of warfare in the
SSM organized by area of warfare. Each worksheet for areas of warfare such as Anti
Air Warfare (AAW), Anti Surface Warfare (ASUW), Anti Submarine Warfare
(ASW), Command Control and Communications (CCC), and air operations is
updated accordingly and systems intended to operate together such as SPY radars
and VLS are grouped and labeled as discrete variables set by the design team. The
worksheet of each area of warfare has all the combat systems related to the Vital
Components (VCs), such as weapons, launchers, sensors, and subsystems, which are
listed and regulated by the weapon or combat system concerned. Individual combat
systems Vital Components (VCs) are included in each variant of the relevant Combat
Systems Equipment List (CSEL) and can be modified as needed to accurately
represent the variant in question. Several combinations of systems and equipment are
built by the design team and are numerically listed under each area of warfare as
potential options to incorporate into the design. Each combination listed accurately
takes into account all weight, space, and power requirements for all associated
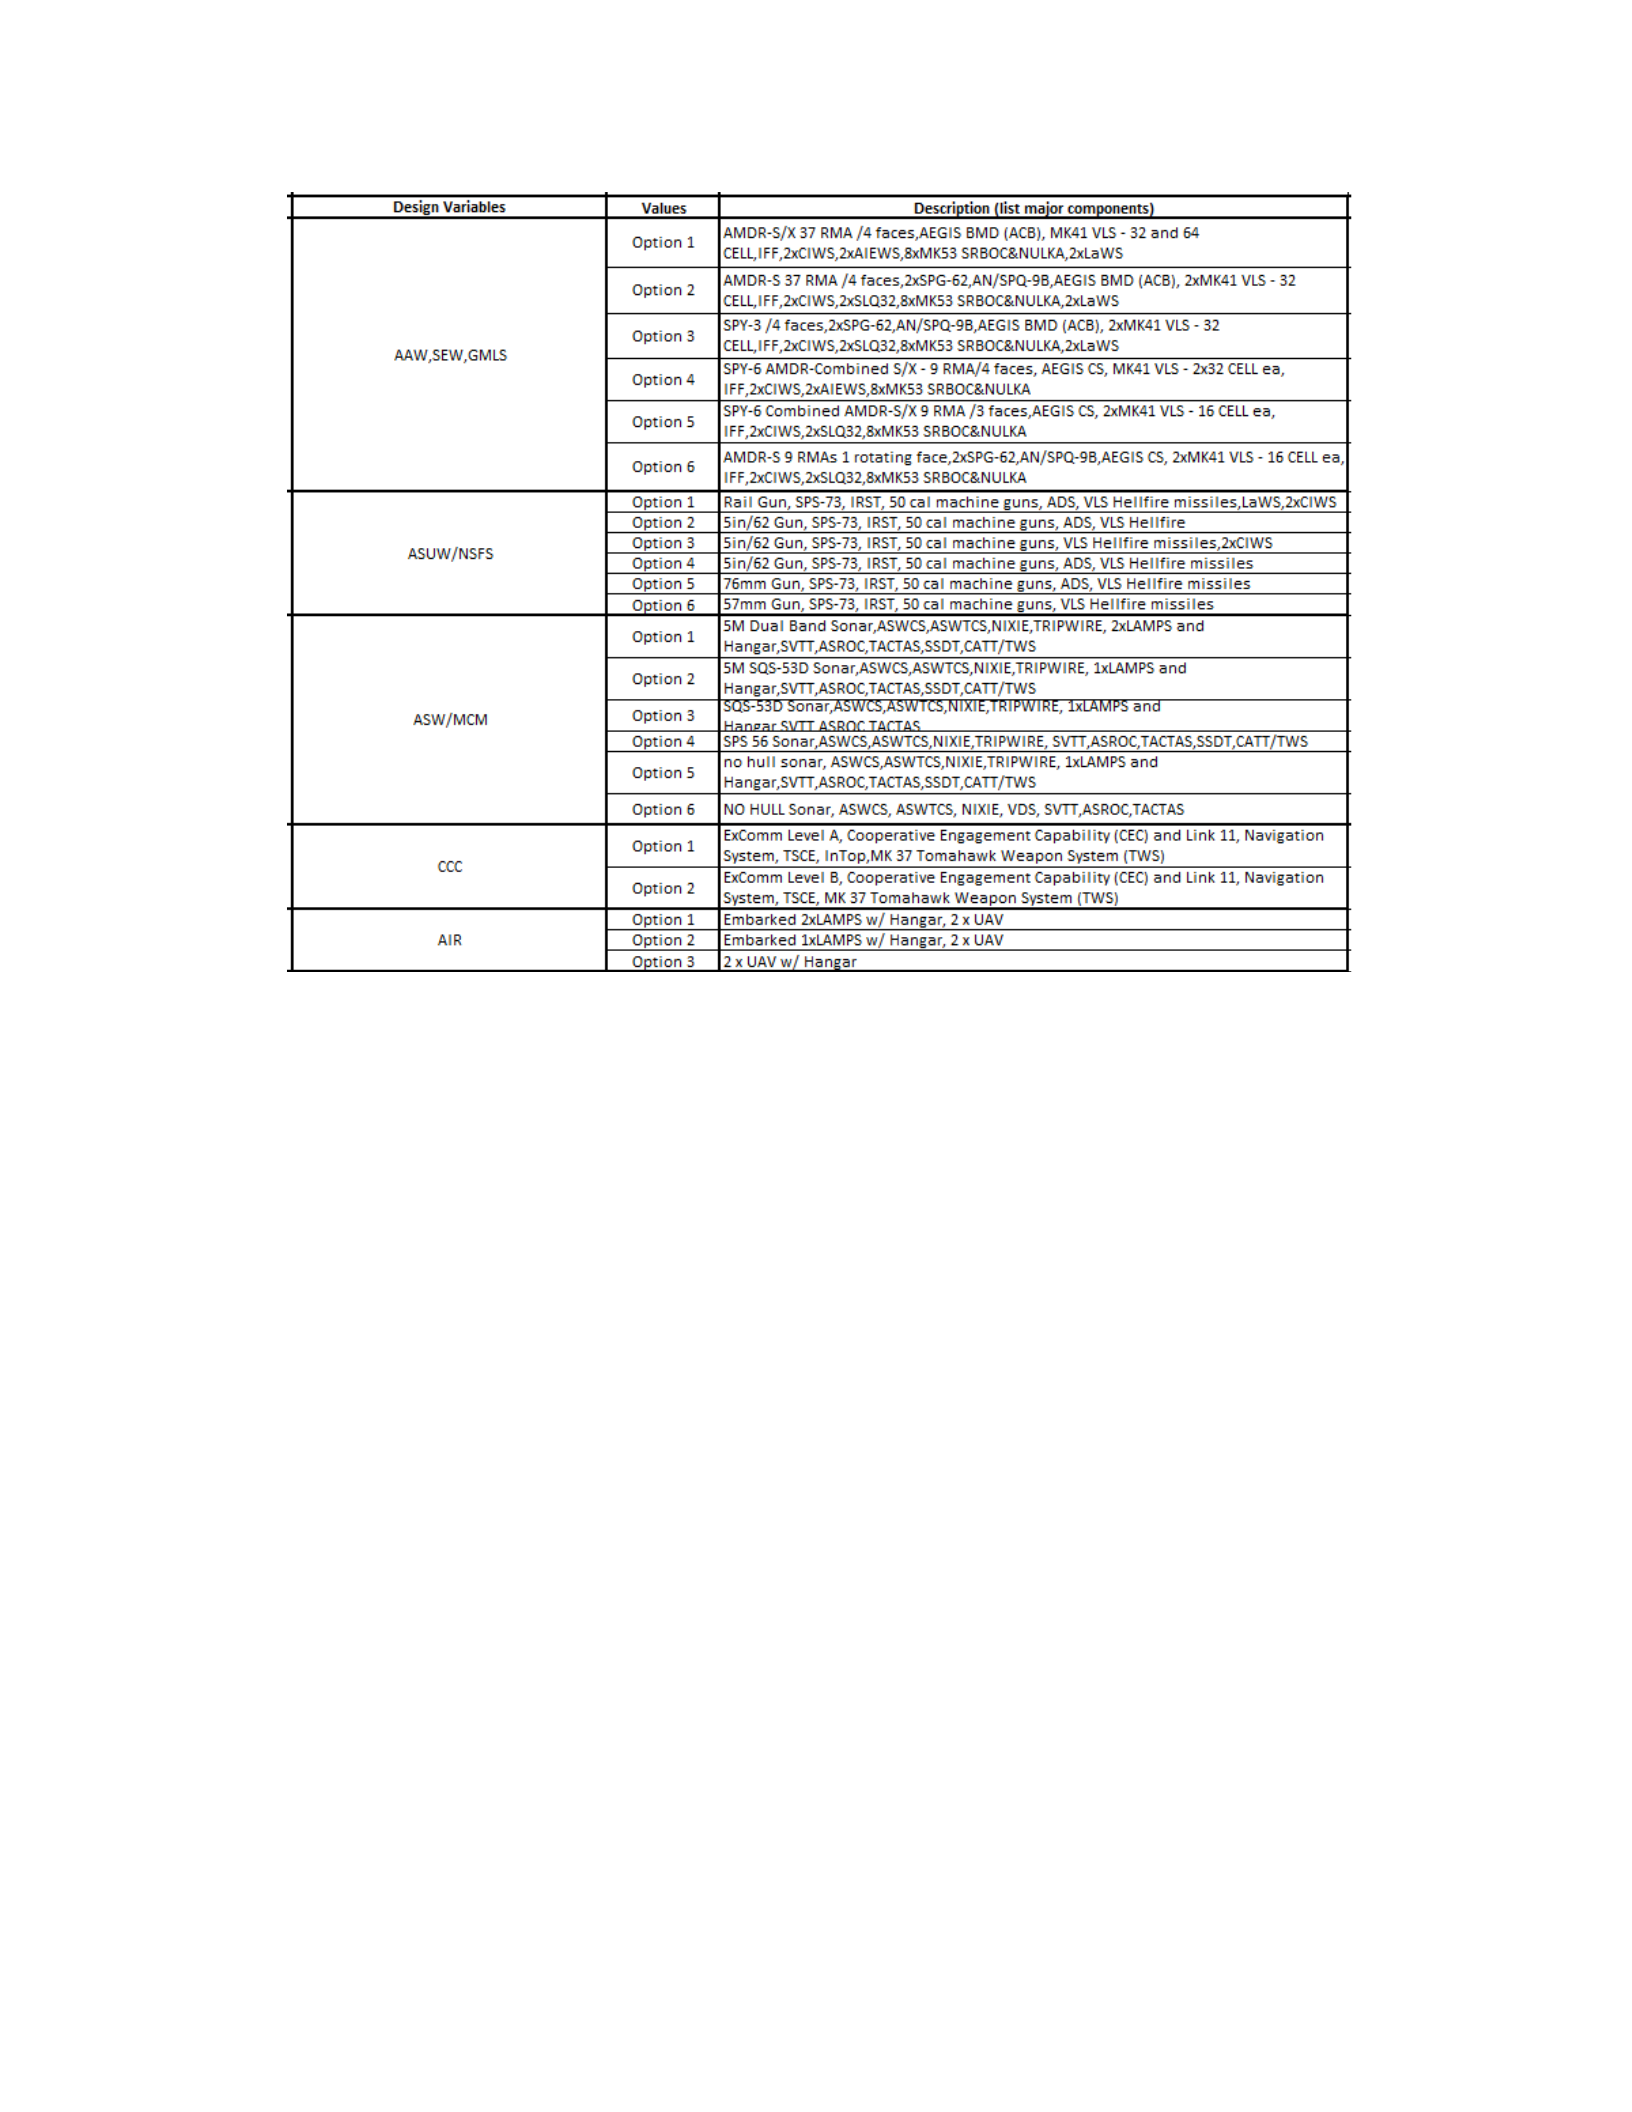
equipment. Table 2.1 below is an example of the combat system options available in
the SSM for medium-sized combatants.
12
Table 2.1: Configuration of Synthetic Model Combat Systems
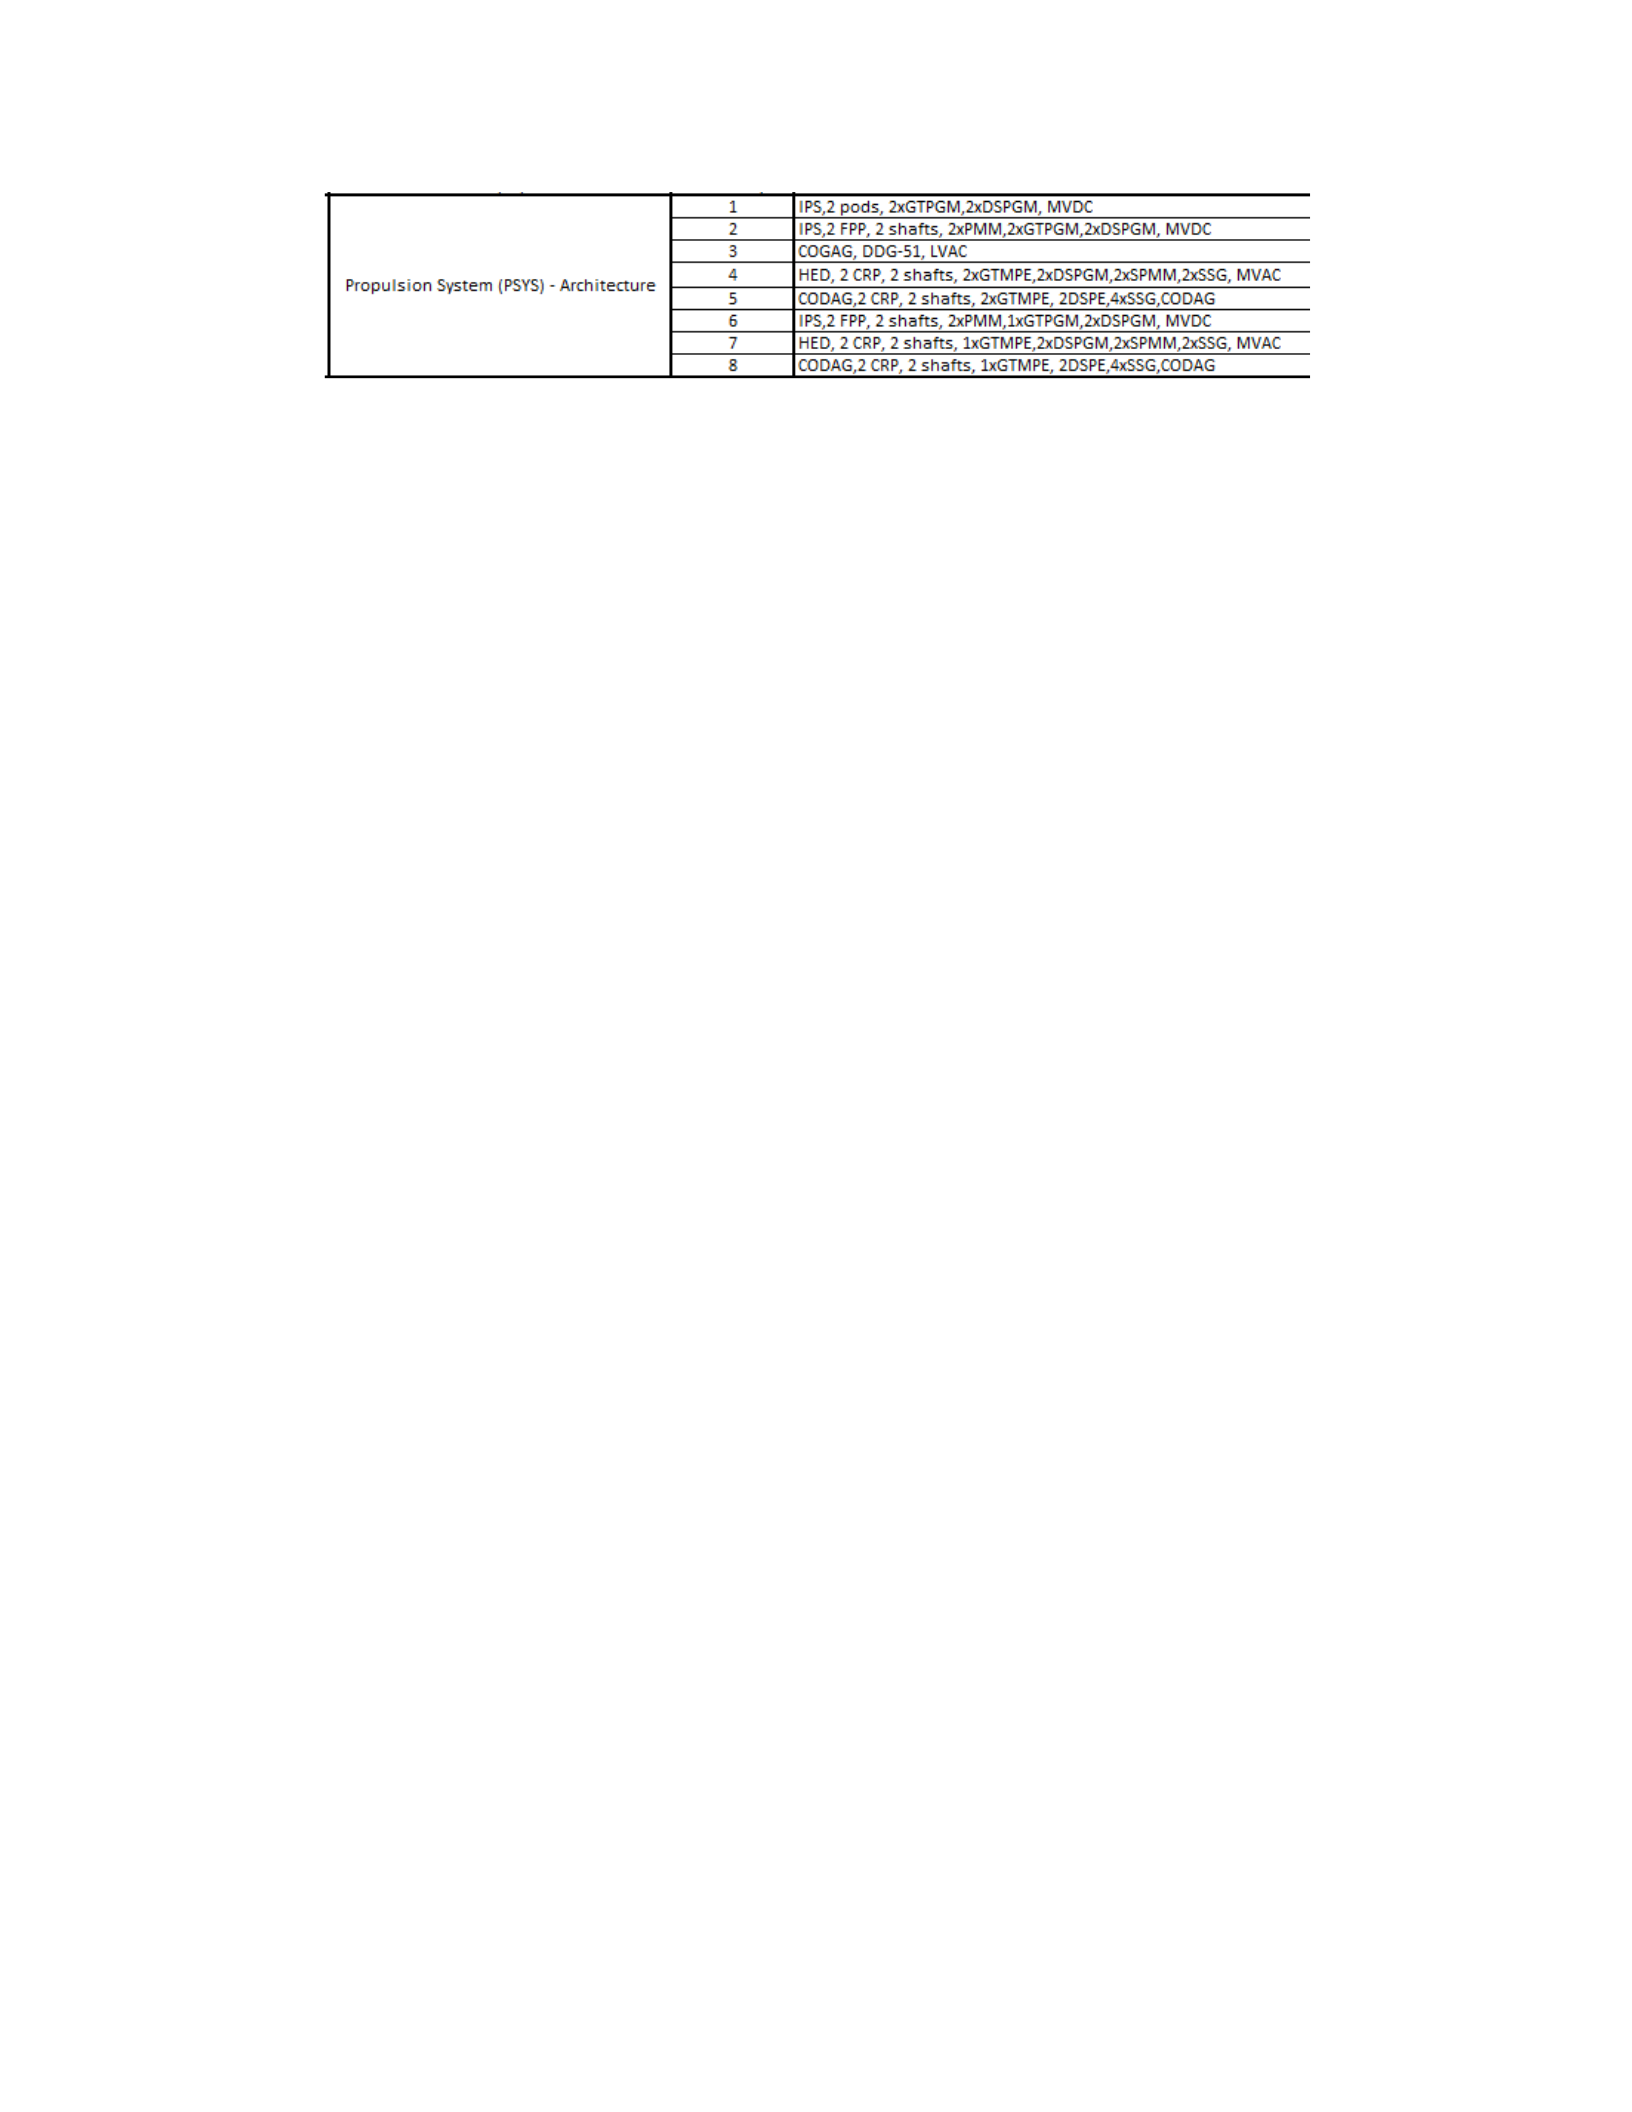
Currently the SSM propulsion system (PSYS) worksheet has 8 different options
for propulsion types and covers the most common warship propulsion configurations
including various configurations of Integrated Propulsion System (IPS), Combined
Diesel and Gas Turbine (CODAG), Combined Gas Turbine and Gas Turbine (CO-
GAG), and Hybrid Electric Propulsion (HED). It is up to the designer to determine
which type of PSYS best suits their design goals, and whether a particular type of
PSYS is not feasible and should be removed from the design space. Some of the
factors that should be considered can be weight requirements, maximum speed,
endurance range, acoustic signature, space constraints, electrical power requirements,
and others such as sponsorship requirements for specific propulsion generator
configurations. The PSYS worksheet also requests a database of engineering
equipment from the Mechanical Equipment List (MEL). An example of a PSYS
configuration is provided below in table 2.2. T h i s i s n o t a n e x h a u s t i v e l i s t
o f V C s i n e v e r y c o n f i g u r a t i o n , a s t h e r e a r e m o r e t h a n 2 0 0
i t e m s f o r e a c h t y p e o f P S Y S .
13
Table 2.2: PSYS Configuration of Synthesis Model
Research completed by CAPT Thomas Trapp (2015) and Mark Parsons (2020)
created dynamic architecture flow optimization (DAFO) where the mechanical VC
size is further optimized based on the ship's DP and DV which provides more
accurate weight parameters and component sizes for each PSYS category to quickly
and accurately scale components to the right size based on the vessel design [1].
T h i s e n s u r e s t h a t t h e V C c h a r a c t e r i s t i c s f o r e a c h t y p e o f P S Y S
a r e a c c u r a t e a n d s a v e s t h e d e s i g n t e a m f r o m t h e t a s k o f p r o p e r l y
m e a s u r i n g e a c h V C f o r t h e d e s i g n , w h i c h w o u l d n o t n o r m a l l y b e
c o m p l e t e d a t t h e c o n c e p t u a l d e s i g n l e v e l .
This design work is very similar to the current process used by 2N students to
update the P&A ASSET table to represent the weight, size, power, and location
information of the VCG for the main components. This is done manually in ASSET
without any form of optimization and needs to be completed before running the
synthesis. C&RE's ship synthesis tools give users more control over the architecture
of the total ship system and the ability to quickly create dirty ads or refine models
without changing unwanted parts of the design. Navy officers who have served
hundreds of hours in engine rooms and combat systems suites greatly benefit from a
higher level of control over the architecture and capabilities of the ship's systems. By
using previous experience, stronger and more accurate decision-making is possible
during the C&RE synthesis model update process. By maintaining a higher level of
control over system-specific marking decisions, the design team can also greatly
increase the likelihood that errors or unintended consequences are discovered much
earlier in the design process, demonstrating a clear advantage over designs in ASSET
where control is much more limited.
14
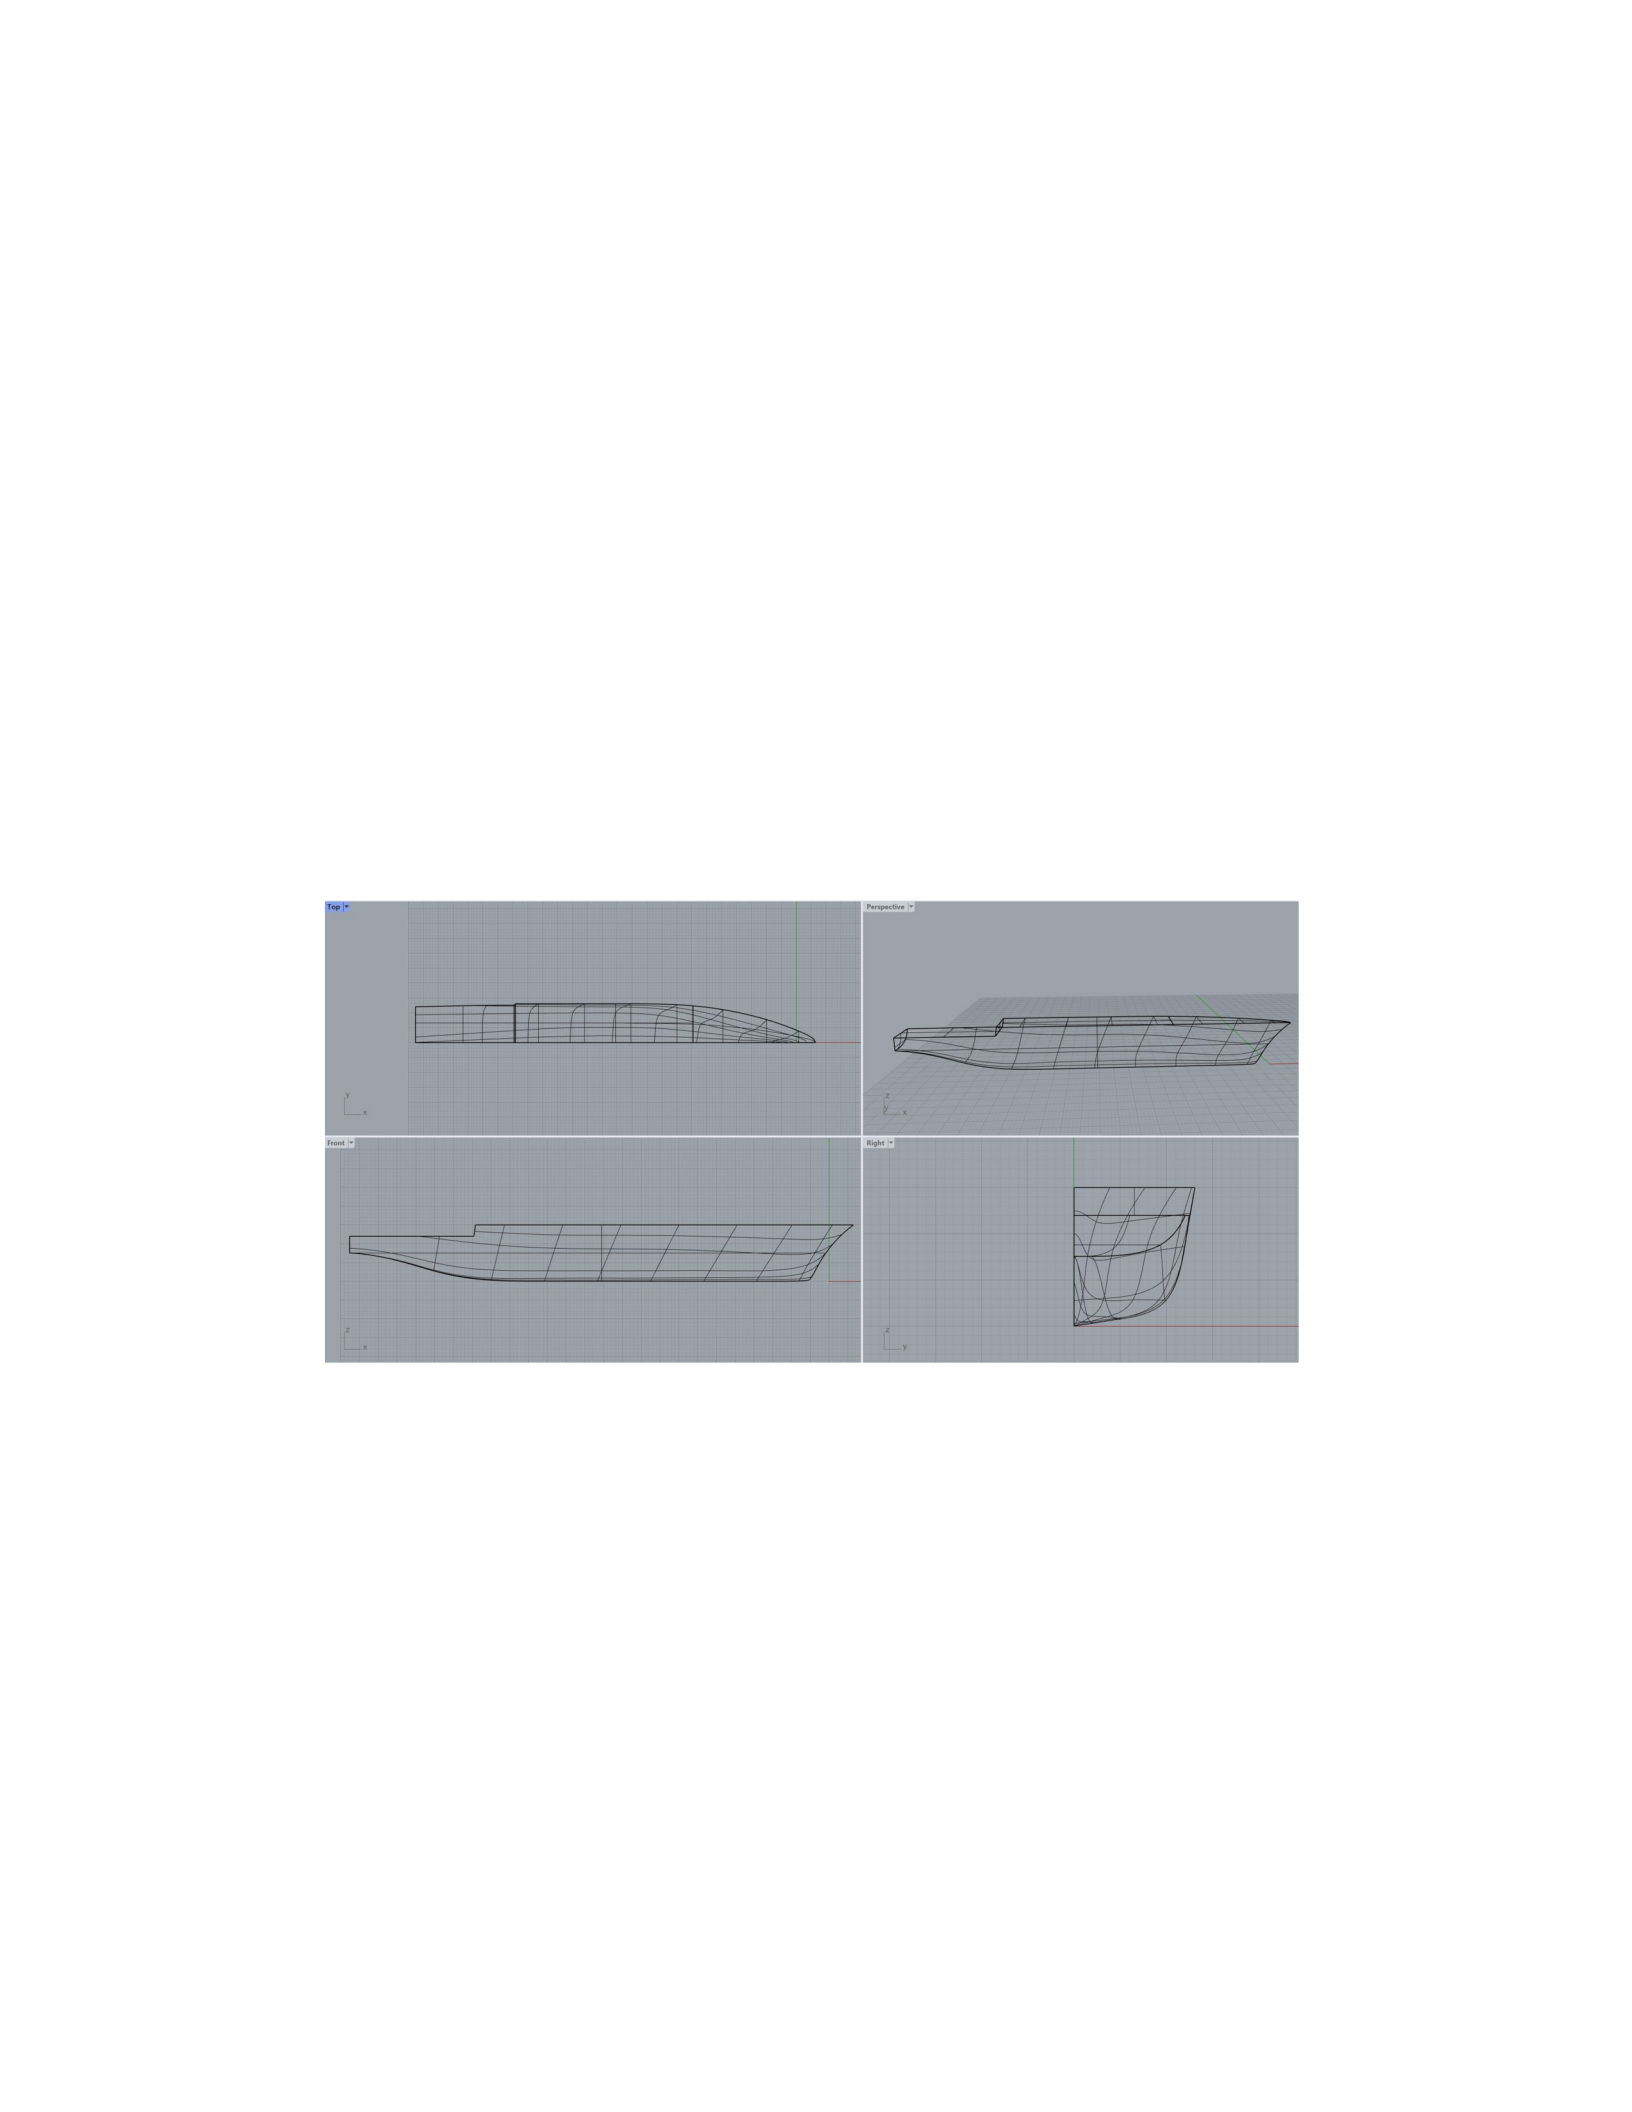
The hull shape design process (#4 in figure 2-1) applies the Design of
Experiments (DOE) approach to create a design space based on the DV of
continuous hull shapes such as Overall Length (LOA), Length to Beam Ratio (LtoB),
Beam to Draft (BtoT) ratio, and other Orca hull shape parameters such as
Longitudinal Prismatic Control, Deadrise Mid, Fwd Fullness, and others that will not
be explained in more detail. In order to limit these variables to create an effective
design space for warships, many known designs were reverse-engineered and fit
models were recreated in Orca to show an acceptable range for hull shape parameters
[6]. T h i s m a t c h i n g m o d e l h e l p s d e s i g n e r s t o a c c u r a t e l y i n s e r t
D V i n t o M o d e l C e n t e r , a n d t h r o u g h t h e u s e o f R h i n o s c r i p t
c o d i n g , M o d e l C e n t e r c a n i n t e r a c t w i t h R h i n o / O r c a 3 d f o r f a s t
h u l l c r e a t i o n .
Figure 2-4: Rapid Hull Manufacturing Center Model using Rhino/Orca3d
This link allows the experimental design to be executed in the Model Center
using Latin-Hypercube or a similar process, chosen by the designer. This allows the
design team to visualize the design space of approximately 200 or more runs and
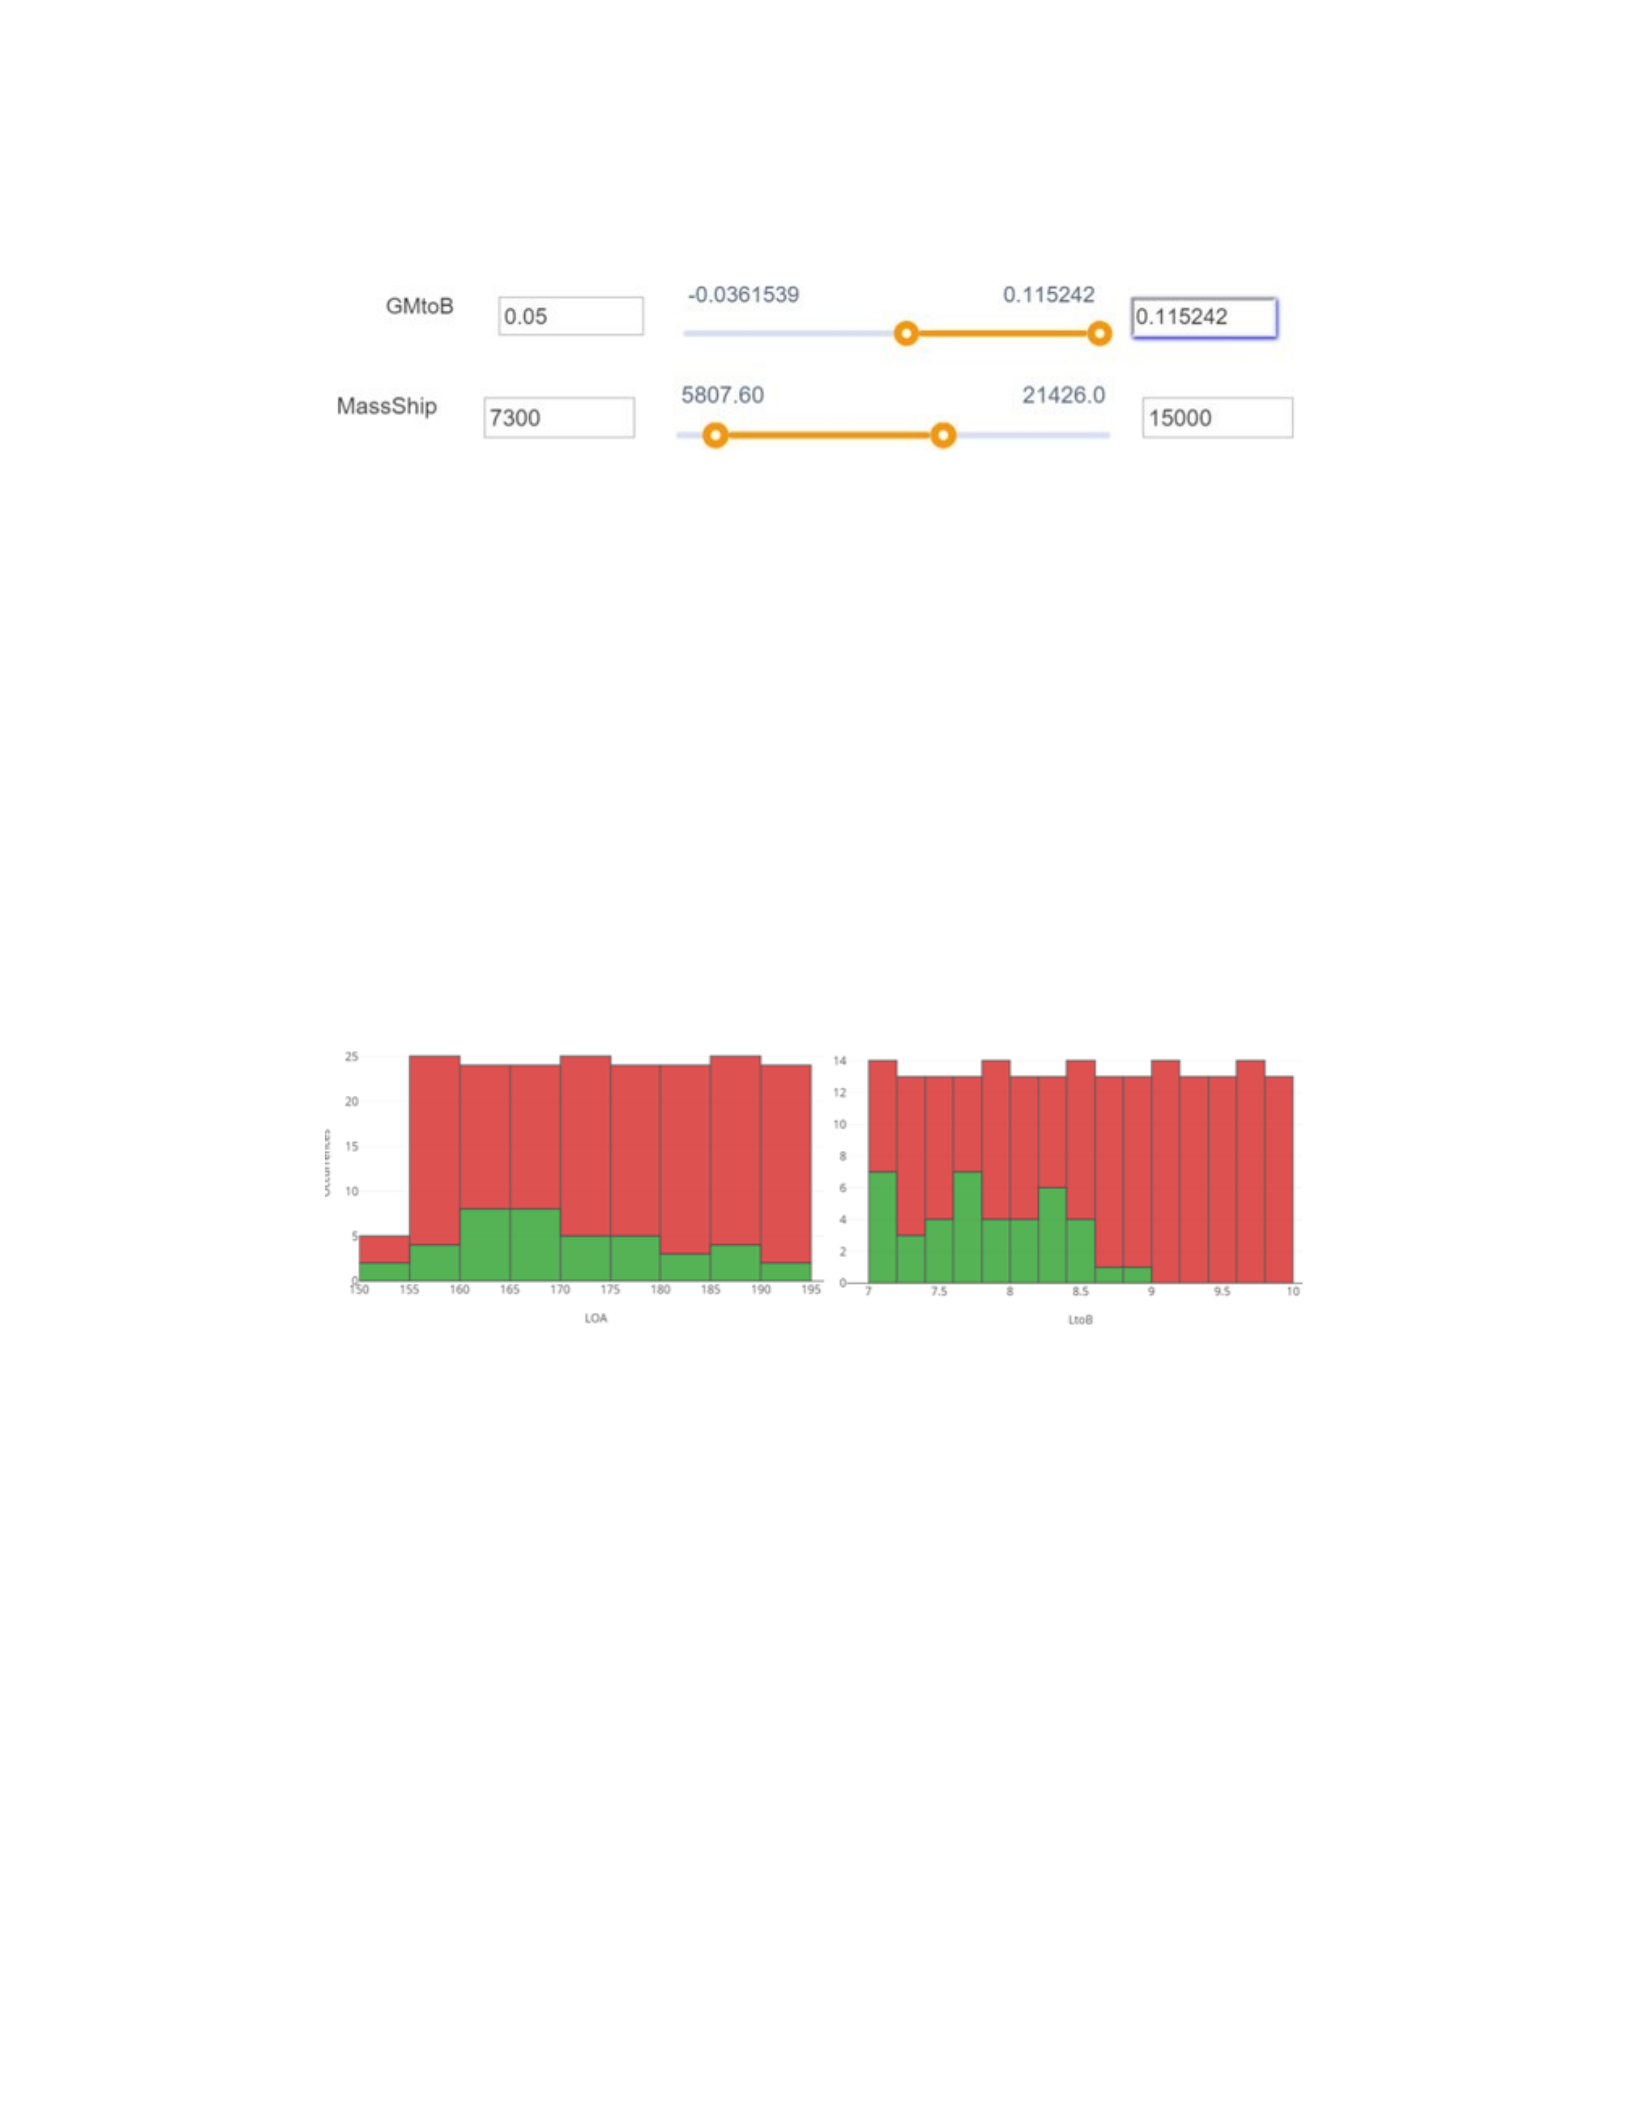
their impact on resistance and power, hydrostatics, and stability. Histograms can be
used to limit DOE response data, and the effects of continuous variables on responses
can be visually identified, which can guarantee potential changes to the design space.
The figure below shows an example where the constraint is placed at the height of
the metacentric to the beam (GMto B) and the continuous displacement (MassShip)
15
variable design space.
Figure 2-5: Examples of Constraints Applied to the Design Space
The following figure shows an example where constraints are placed on the
overall length (LOA) and the length-to-beam ratio (LtoB) of the design space. The
red part shows the DOE experiment filtered by the constraint, and the green part
shows the experiment within the constraint. Constraints on the design space can
greatly affect the number of valid experiments in the DOE, and a visual analysis of
the effects of these constraints could potentially warrant rerunning the DOE to better
capture the appropriate design space.
Figure 2-6: Histogram Showing the Effect of Constraints on the Design Space In
the center of the model, the PD strip is used to calculate the seaworthiness
characteristics using
Strip theory. Holtrop resistance analysis is run in Matlab, and a separate Matlab
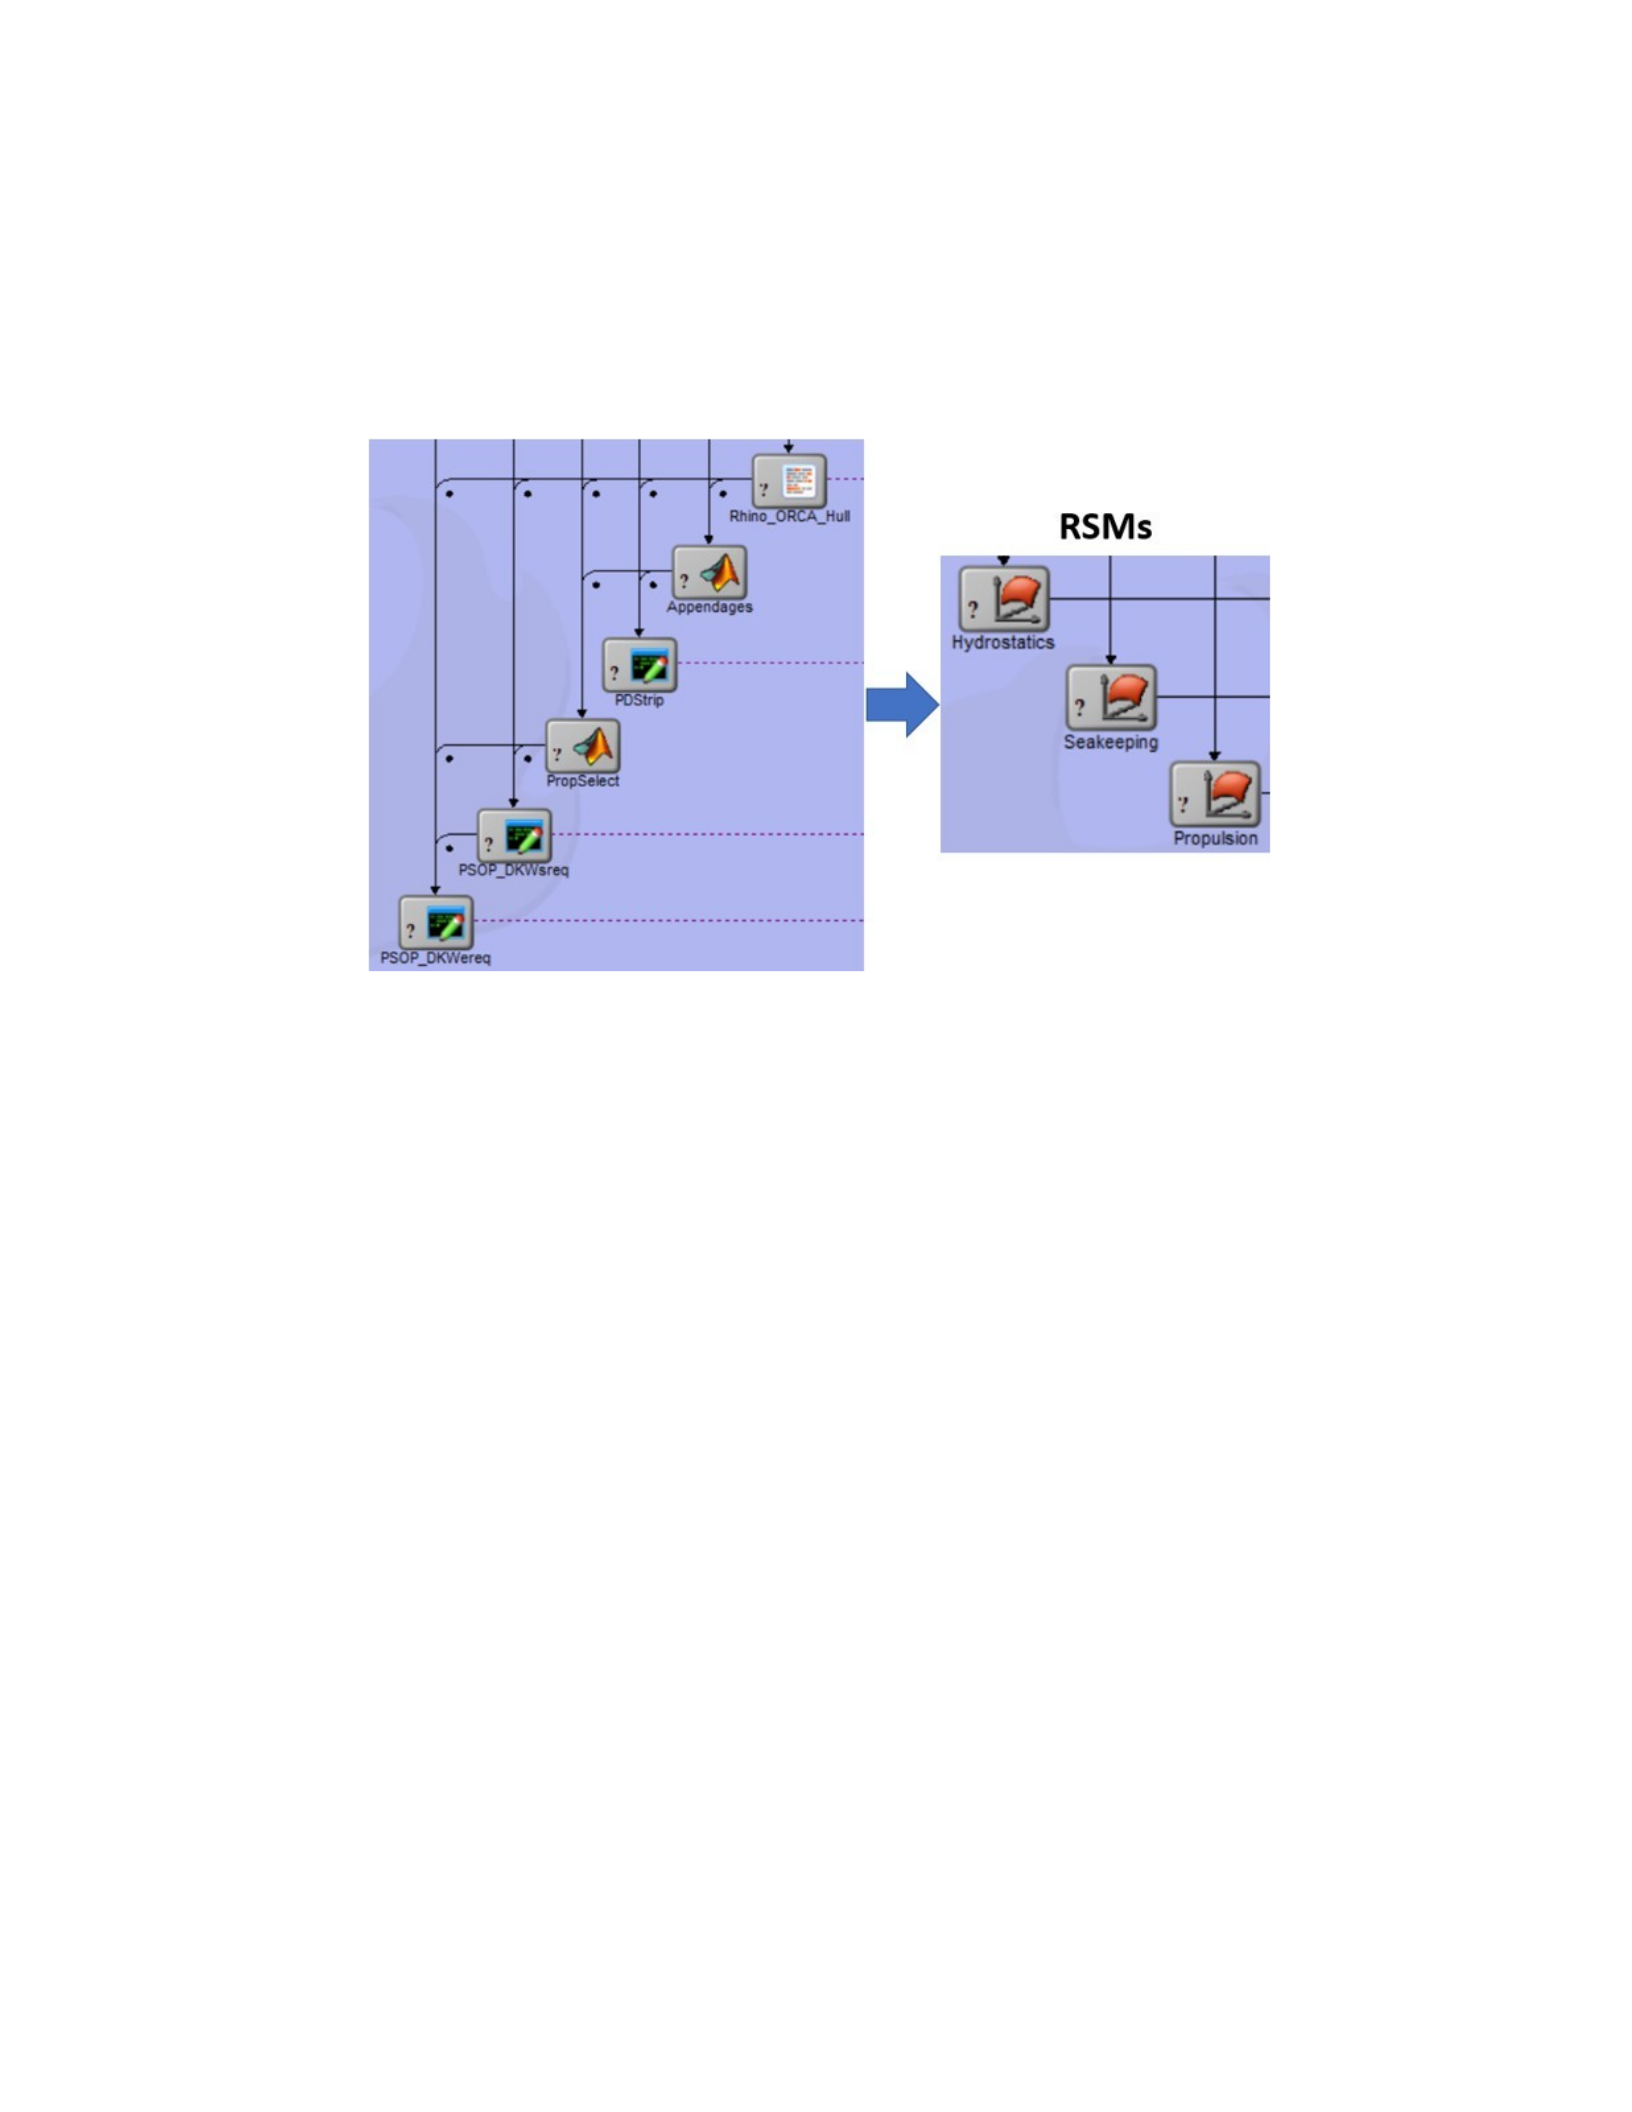
module runs the PSOP SNAME program for propeller design [1]. T h e p o w e r
r e q u i r e d f o r t h e p r o p e l l e r is t h e n c a l c u l a t e d f o r dur a b i l i t y a n d
s u s t a i n e d s p e e d ( d e s i g n ) . I f c h a n g e s m u s t b e m a d e t o c a p t u r e a
m o r e a c c u r a t e r a n g e o f o n e o r m o r e c o n t i n u o u s v a r i a b l e s , t h e
f i n a l D O E i s r u n p r i o r t o t h e d e r i v a t i o n o f t h e R e s p o n s e S u r f a c e
M o d e l ( R S M ) o f h y d r o s t a t i c , m a r i n e m a i n t e n a n c e , a n d p r o p u l s i o n
16
d a t a f o r u s e i n M u l t i - P u r p o s e G e n e t i c O p t i m i z a t i o n ( M O G O ) i n
f u r t h e r a n a l y s i s . R S M
generated from the DOE tool in the Model Center and
labeled hydrostatic, marine maintenance, and propulsion as shown in figure 2-7
below.
Figure 2-7: RSM Generation in the Model Center [1]
This RSM represents the hull generated in Rhino/Orca, while the synthesis model
organizes the design and performs all further calculations including OMOE and
OMOR calculations. The ultimate goal of MOGO is to explore the design space to
create a non-dominated ship design frontier ranked by cost, OMOE, and OMOR [6].
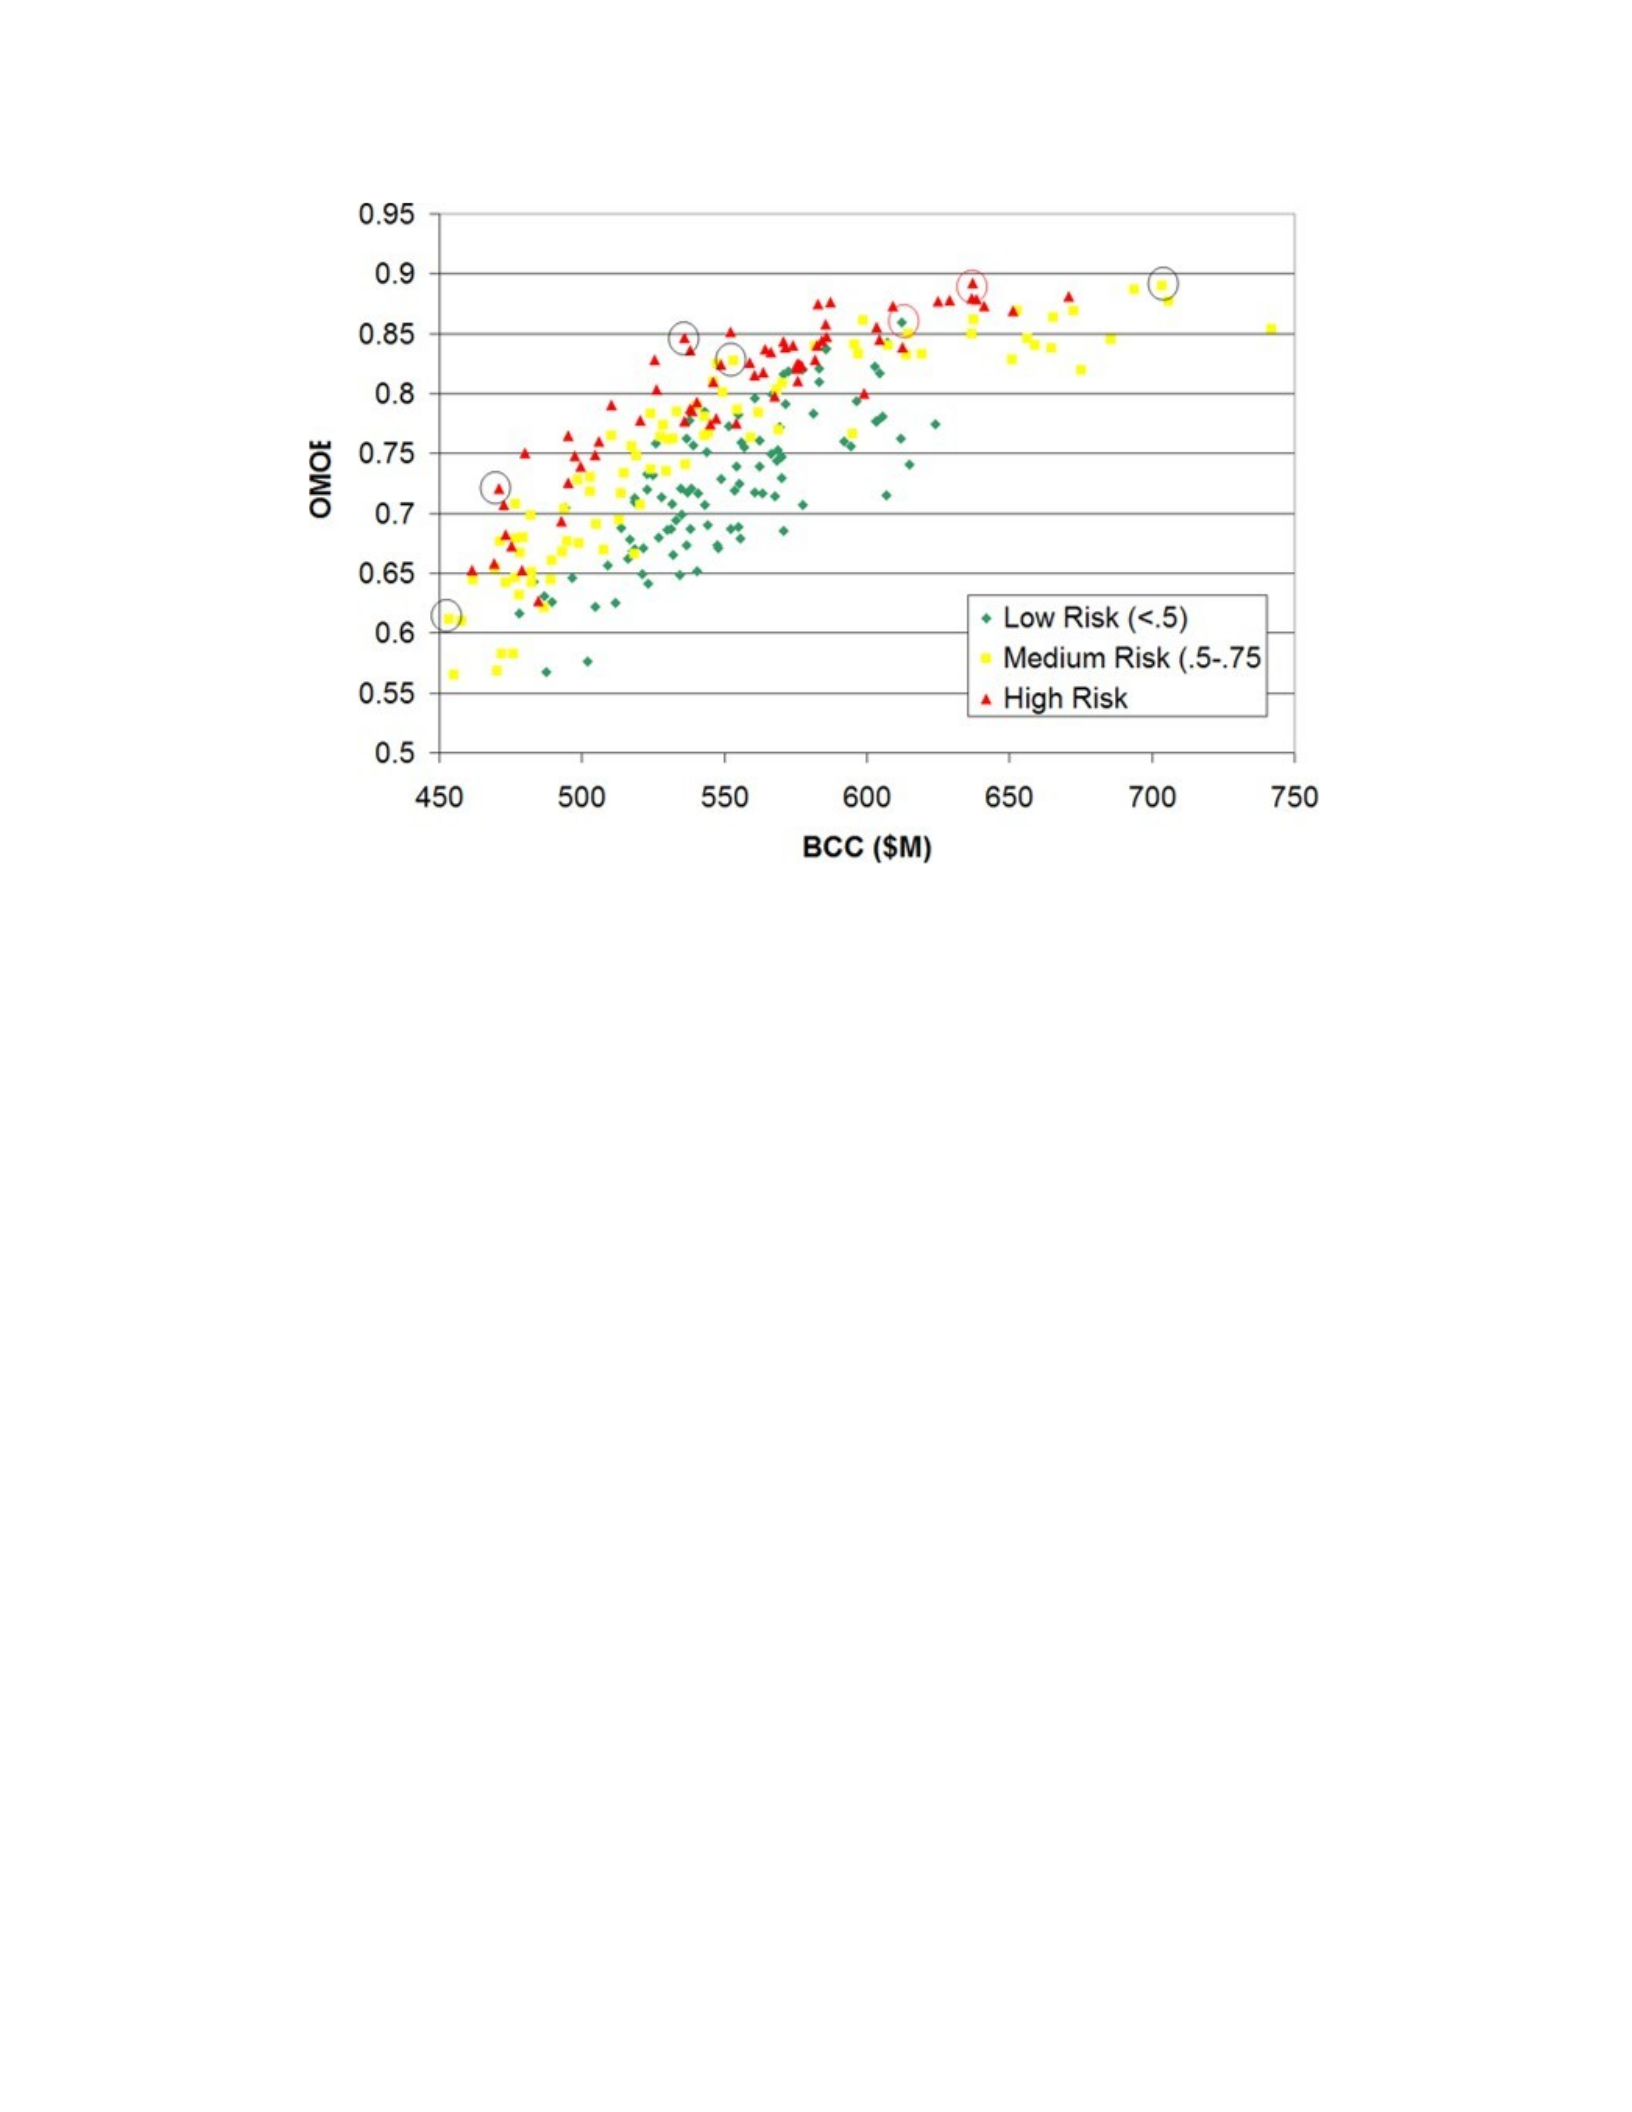
Figure 2-8 below shows the MOGO results for a medium-sized surface combatant.
Costs versus OMOE are plotted for each variant, and each variant is colored based on the
calculated OMOR value. These OMOR values are calculated by the OMOR worksheet in
SSM, and are set by the Model Center based on the design team's preferences. In this case,
the OMOR value has been set as low (green) for values less than 0.5, medium (yellow) for
values 0.5 to 0.75, and high (red) for values above 0.75. Planning these variants as shown
gives the design team an excellent visual reference of the undominated frontier and goes a
long way in choosing the preferred variant.
17
Figure 2-8: OMOE vs. Fees for Surface Vessels [1]
Once the selected variant has been selected, it can then be repeated using further
single-objective optimization techniques that are typically focused on minimizing a
single parameter such as cost, or maximizing a single parameter such as sustained
speed. Once all the optimizations are complete, the resulting DV can then be easily
loaded back into the SSM and a new hull can be generated in Rhino/Orca and is now
ready for subdivision.
C&RE tools provide a clear and logical path to DOE, MOGO, and non-
dominated frontier analysis that includes cost, OMOE, and OMOR. This is a clear
advantage over ASSET, which lacks this feature, and also an advantage over the
creation of project-specific design tools that may or may not be useful to future
design teams. There are many examples in the 2N program of powerful design tools
that are created and used for only one ship sign for various reasons. Individual design
tools can and still should be created in some cases, although the obvious advantage is
also that they can interact with Model Center and Rhino/Orca which will allow for
the future growth of MIT's design tool packages. Popular coding languages such as
Matlab, Excel, and Python

18
easily integrated with C&RE tools and is another obvious advantage that increases
the likelihood that naval officers in the 2N program will be able to successfully
contribute to improving the tool through future research.
19
Article 3
New method to complete the initial
setup
3.1
Current Initial Setup Process
Once steps 1-8 of the C&RE process shown in Figure 2-1 are completed, the three-
dimensional hull including the superstructure has been created in the Model Center.
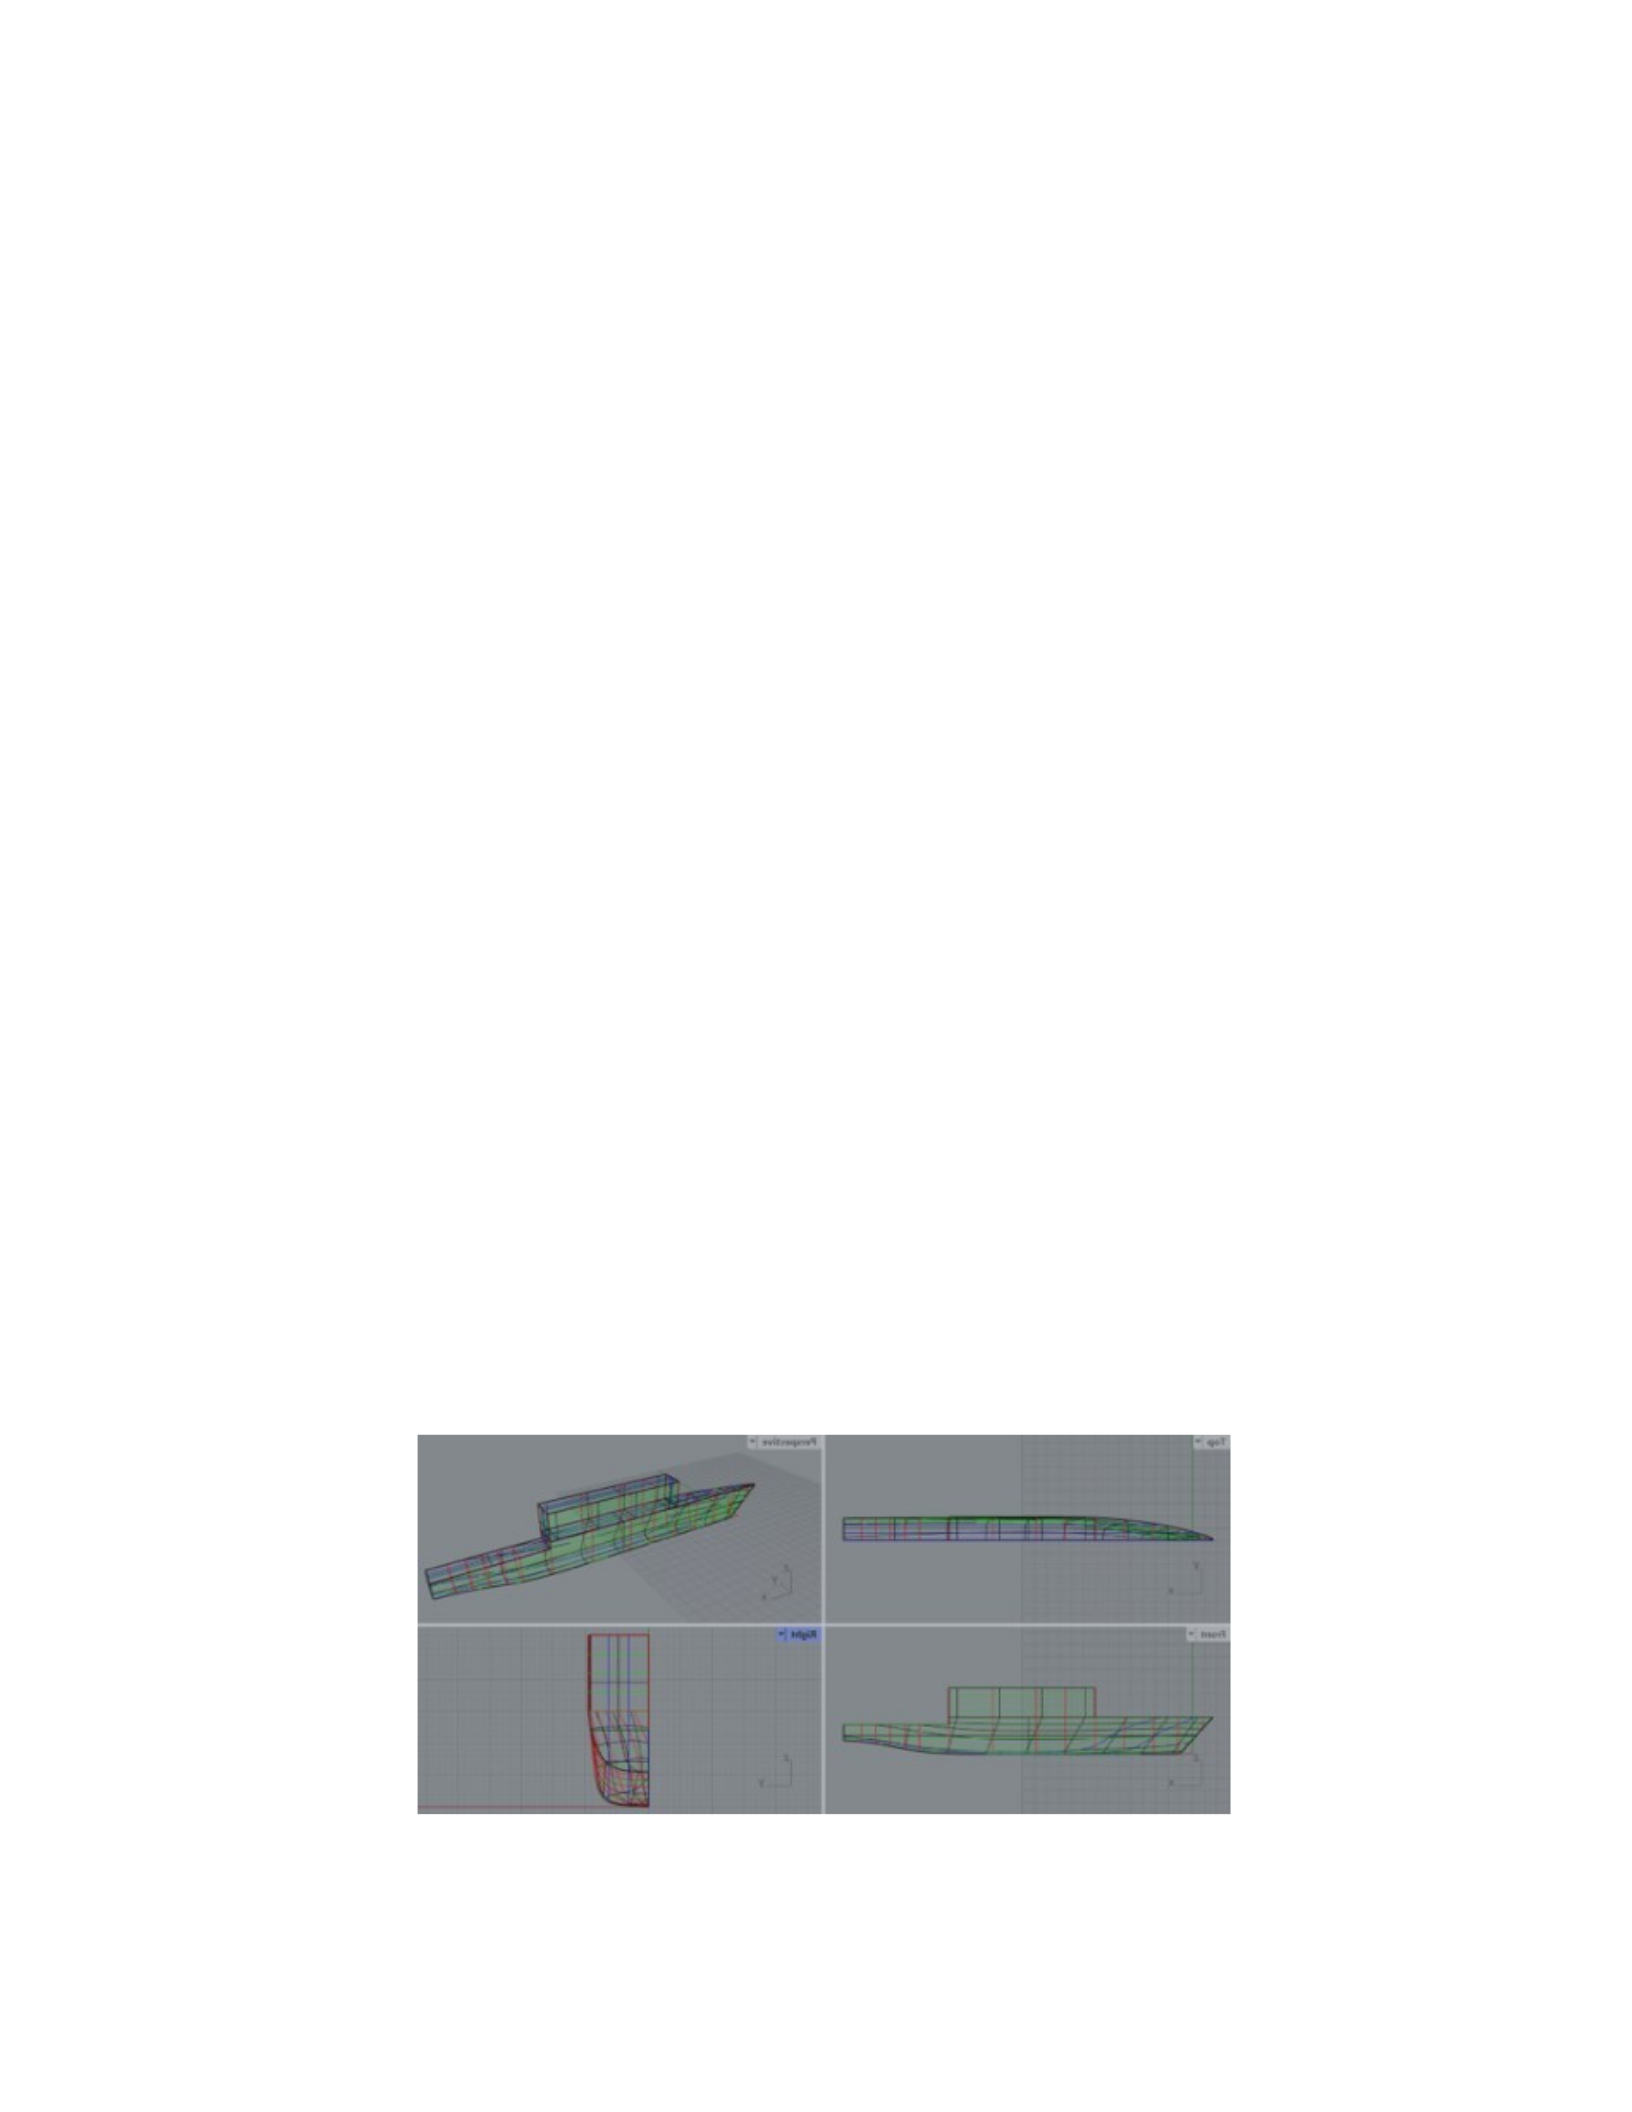
An example of the resulting stomach is shown below. The deckhouse design is
driven by volume and area calculations that can be set based on user input into the
SSM. The physical shape of the deckhouse will be modified by the design team as
necessary to meet further criteria such as wind resistance, radar cross-section,
interference between top-side equipment, or general aesthetics.
Figure 3-1: Three-Dimensional Hull with Superstructure Generated in Rhinos

20
The design team can now focus on the Physical Architecture component of the
C&RE process shown as steps 10-14 in figure 2-1. D u r i n g t h i s p h a s e , t h e
h u l l i s s u b d i v i d e d b y t r a n s v e r s e b u l k h e a d s , l o n g i t u d i n a l
b u l k h e a d s , a n d h o r i z o n t a l d e c k s . T h e r e a r e s e v e r a l m e t h o d s
t o c o m p l e t e t h e h u l l s u b d i v i s i o n b u t t h e m o s t c o m m o n
a p p r o a c h i s t o m a n u a l l y c r e a t e a n d p l a c e t h e R h i n o
p o l y s u r f a c e r e p r e s e n t i n g t h e b u l k h e a d a n d d e c k a t t h e i r
r e s p e c t i v e l o c a t i o n s c a l c u l a t e d b y t h e M o d e l C e n t e r d u r i n g
s t e p 1 0 o f t h e C & R E p r o c e s s . T h e h u l l s u b d i v i s i o n m o d u l e i n
t h e M o d e l C e n t e r i s t h e m a i n r e f e r e n c e f o r p l a c i n g b u l k h e a d s
a n d d e c k s u n l e s s f u r t h e r d e c i s i o n s a r e m a d e t o a c c o m m o d a t e
c o m p a r t m e n t s t h a t m a y r e q u i r e a d j u s t e d d i m e n s i o n s . O n c e t h e
s u b - d i v i s i o n i s c o m p l e t e , t h e i n i t i a l s e t u p o f t h e V C c a n
b e g i n , a n d t h i s i s c o m p l e t e d b y u s i n g a s e p a r a t e m a n u a l
p r o c e s s . D e s i g n e r s h a d t o m a n u a l l y c r e a t e m o r e t h a n 4 0 0
i n d i v i d u a l R h i n o o b j e c t s r e p r e s e n t i n g V C s w h i c h w e r e t h e n
a s s i g n e d t o t h e o r c h e s t r a t e d R h i n o l a y e r s y s t e m . T h e V C c a n
t h e n b e s e t u p i n s i d e t h e a p p r o p r i a t e c o m p a r t m e n t , a n d v i s u a l
a n a l y s i s o f t h e s e t u p c a n h i g h l i g h t p o t e n t i a l s y s t e m g l i t c h e s
o r p r o b l e m a t i c s p a c e l i m i t a t i o n s w i t h i n t h e c o m p a r t m e n t .
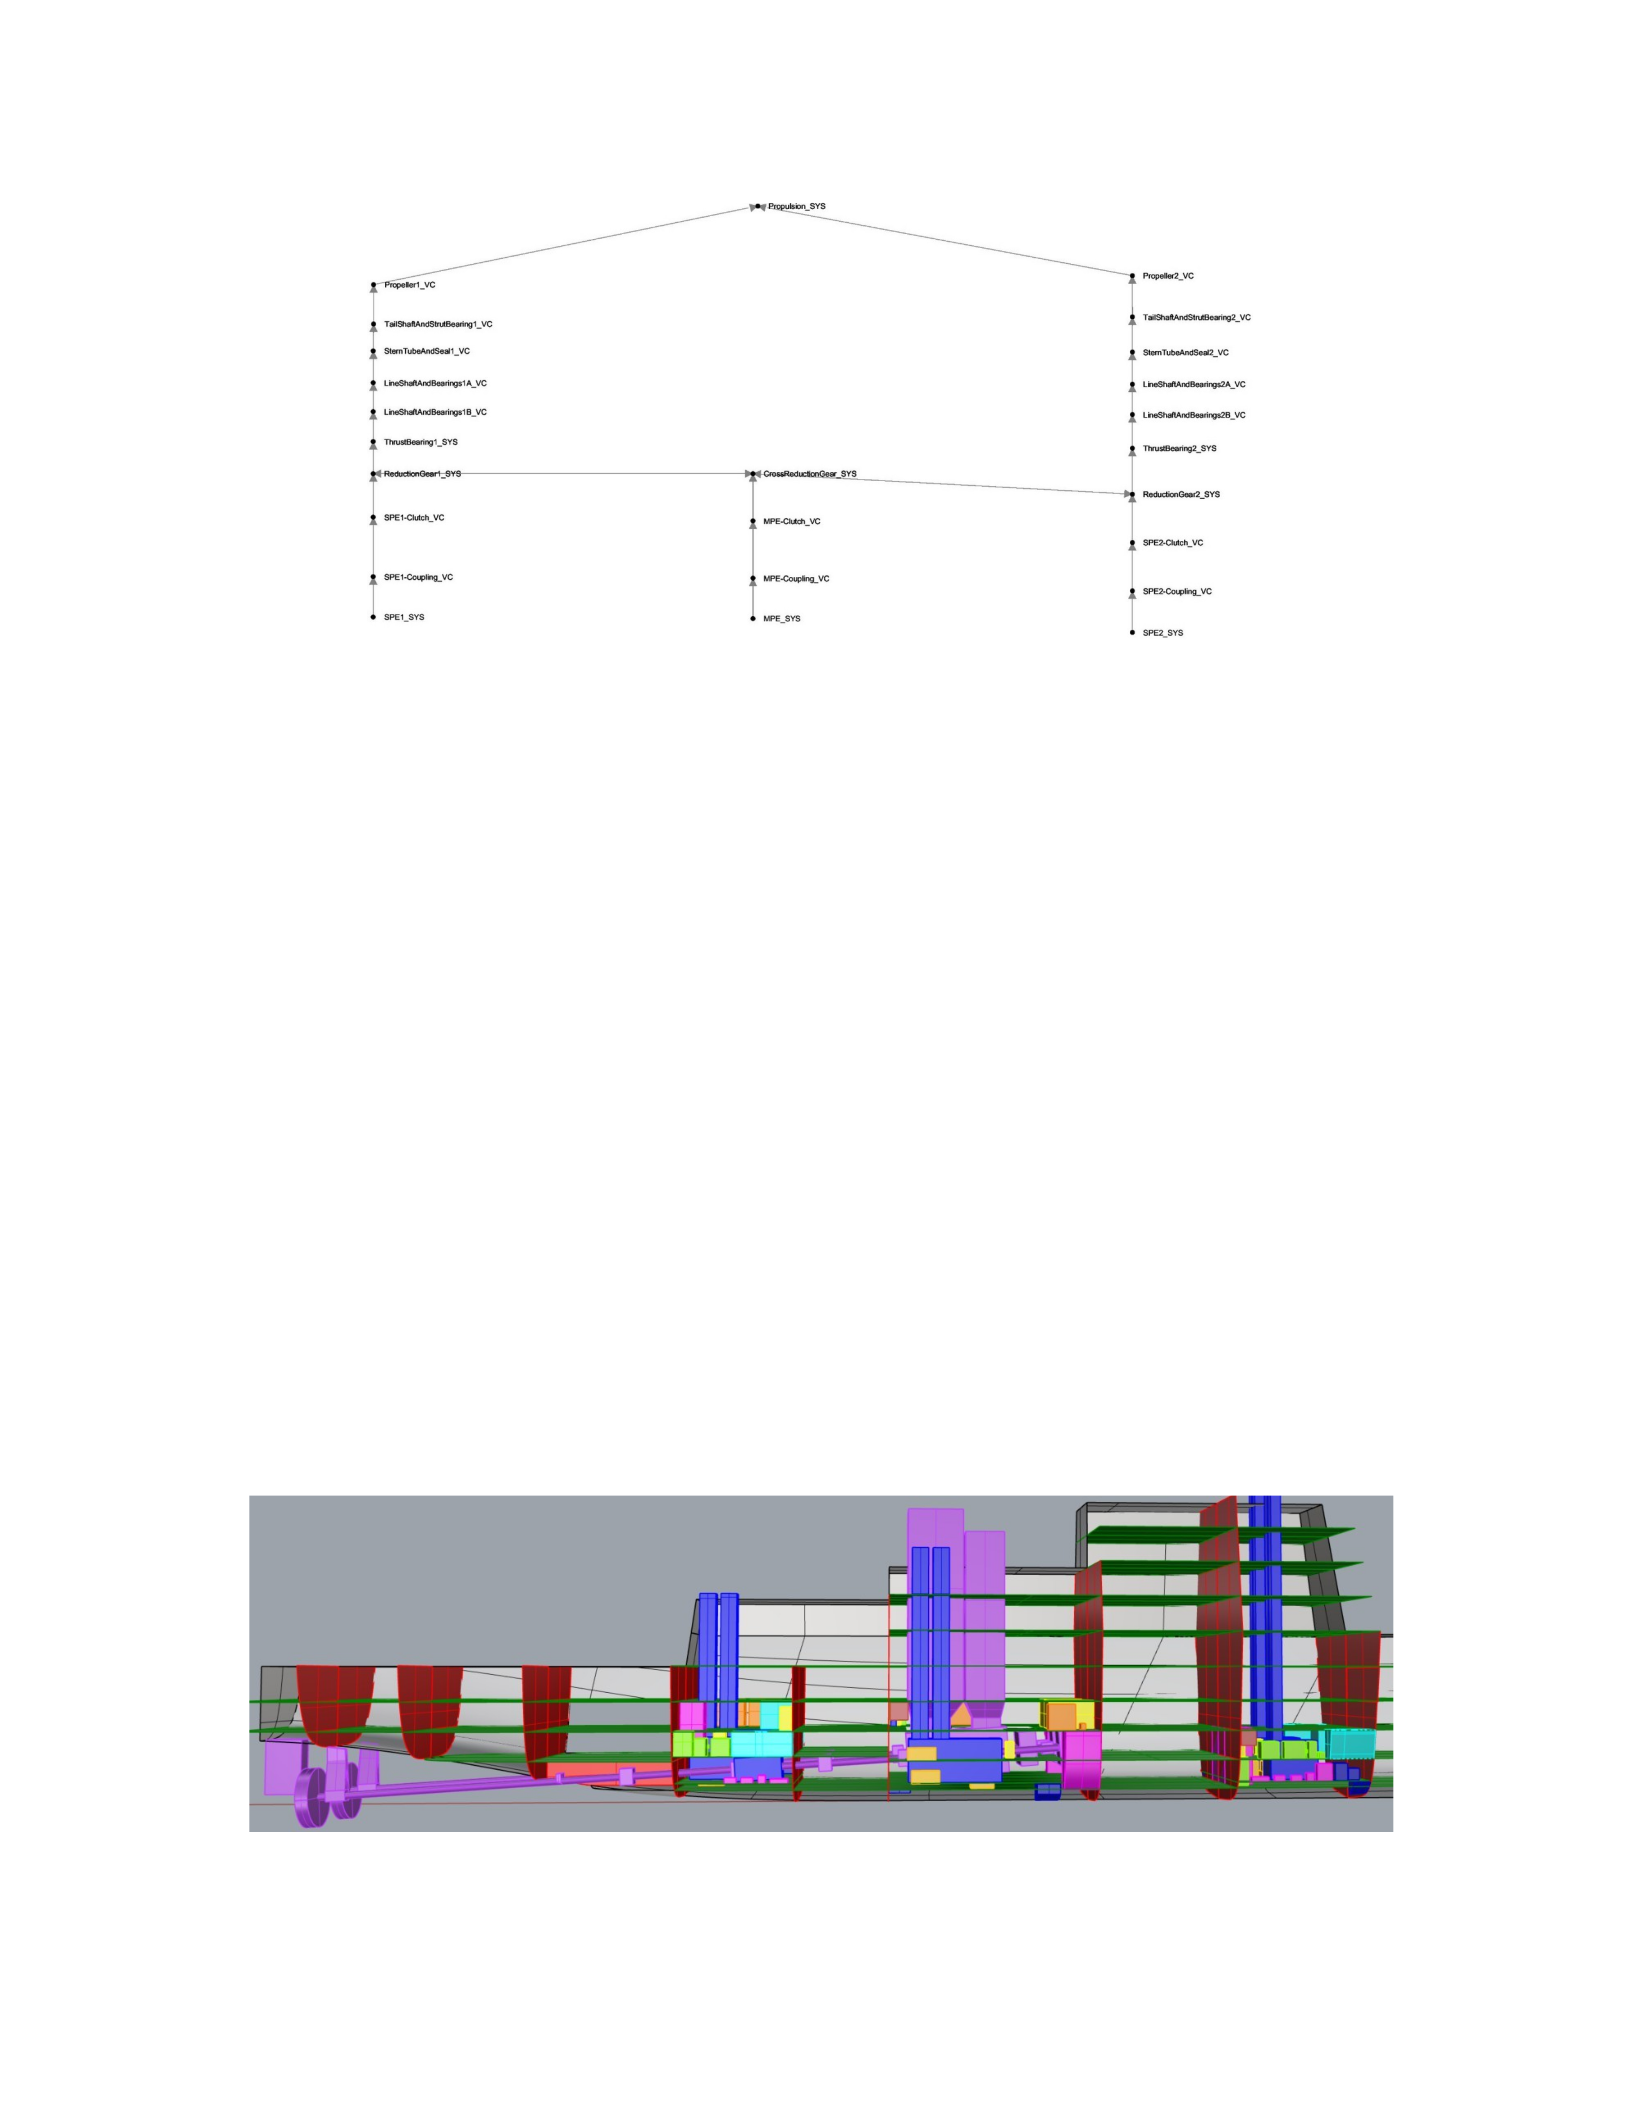
N o d a l d i a g r a m s s h o w i n g t h e l o g i c a l a r c h i t e c t u r e o f a
p a r t i c u l a r s y s t e m a r e u s e d t o a i d i n t h e s e t u p p r o c e s s [5]. T h e
l o g i c a l a r c h i t e c t u r e o f a s y s t e m c a n b e t h o u g h t o f a s a l i n e o r
b l o c k d i a g r a m . A n e x a m p l e o f a n o d a l d i a g r a m f o r a n e w f r e t -
d e s i g n p r o p u l s i o n p l a n t i s s h o w n b e l o w i n f i g u r e 3-2. T h i s
d i a g r a m i s u s e d t o a i d i n t h e s e t u p o f a m e d i u m - s i z e d s u r f a c e
c o m b a t a n t f e a t u r i n g a h y b r i d e l e c t r i c d r i v e p r o p u l s i o n
s y s t e m .
21
Figure 3-2: Nodal Diagram for Hybrid Electric Propulsion Generator
If the VC cannot be fitted into the hull according to the logical architecture of the
system, or there is a problematic interference between the systems, the design may be
declared unfeasible due to conflicts with the area or the adjustable volume. This
process is very demanding because there are over 400 VCs enrolled in SSM and
above-average Rhinoceros skills are required to complete the initial setup accurately.
The biggest challenge occurs when VCs that require a large amount of internal space
are placed in their respective locations while further supporting subsystems must be
arranged according to the logical architecture of the larger system. Simultaneously,
designers must also carefully account for potential interference between systems in
three dimensions. Figure 3-3 shows an example of a surface vessel that has been
manually subdivided with a Rhino Poly surface, and the initial setup has been
completed in the main engineering room with a manually constructed VC.
Figure 3-3: Manual Subdivision and Initial Setup

22
As seen in figure 3-3, it is possible to achieve a high level of detail at the level of
concep-tual design using this method. Designers with operational experience in the
battleship's engine room are at a clear efficiency advantage during the process of
dividing the hull and setting up the VC. The engine room can be set up with
confidence by calling upon hundreds of operational hours spent by surface warfare
naval officers in many classes of ships. Designers without experience on surface
vessels are at a disadvantage and without guidance from references such as detailed
ship information books, which cannot be released to the public, the manual VC setup
process can experience inefficiencies and lower confidence in the design. Therefore,
the information for VC found in the SSM such as compartment assignments,
dimensional information, and system nodal diagrams is the main reference for initial
setup during the C&RE design process. To improve the manual process of
subdivision and initial setup, a new tool was sought that could leverage critical
component data from the SSM to perform initial setup more effectively and could be
incorporated into the C&RE process.
3.2
New Process for Preliminary Setup
The new tool needs to implement as much automation as possible for the initial setup
process described above while also providing a more efficient method for creating
and setting up more than 400 VCs that need to be set up. Incorporating automation
into this process will increase efficiency by eliminating some user error without
compromising the overall learning experience in completing the ever-complex initial
setup of a warship. Since the three-dimensional hull shape is generated by the Model
Center using Rhino, this new initial setup tool should also be able to easily interact
with Rhino to reduce complexity.
It was initially believed that macros written in Rhino script coding would be able
to achieve this goal. An attempt was made to trace the exact sequence of Rhino
commands required to construct a Rhino object representing VC, and then use this
command sequence as the basis for creating macros. The ultimate goal of

23
This macro will quickly generate Rhino objects for all VCs, arrange them into layers,
and then place them in the appropriate locations according to the x,y,z location
information found in SSM. This attempt failed, as more training in Rhino scripts was
needed to create coding that was powerful enough to accomplish all of the tool's
goals. Therefore, new methods for creating tools using different naval architecture
software are sought. Paramarine software packages were investigated as a viable
option, but ultimately it was considered that the learning curve for the use of this
software was effectively too steep for an academic environment due to the low level
of experience with Paramarine.
The search into the Rhinoceros design tools used by architects was carried out on
the basis that large ships and buildings have an integrated system that covers various
levels. This leads the search to the Rhino Grasshopper plug-in application, which is
an interactive python coding platform with a user-friendly graphical user interface
that is very similar to Rhino and capable of creating powerful macros through python
templates. These macros are represented by displaying ter-terminal inputs and
outputs that can be connected to encoding that are visually represented by cables.
After an initial investigation into the feasibility of using Grasshopper to develop a
new tool, it was discovered that the Grasshopper Bumblebee2 plug-in can quickly
read excel data defined by a specific file path and import a specific range of excel
worksheets into Grasshopper. This finding is very strong because now all the
dimensional and location information for VCs under the ShipSYSnew worksheet
from SSM can now be imported and used in Grasshopper to create and place Rhino
objects that represent VCs.
To reduce complexity, it's a good idea to reduce the amount of data read and imported
by excel readers. This is achieved by importing two specific cell ranges that contain the
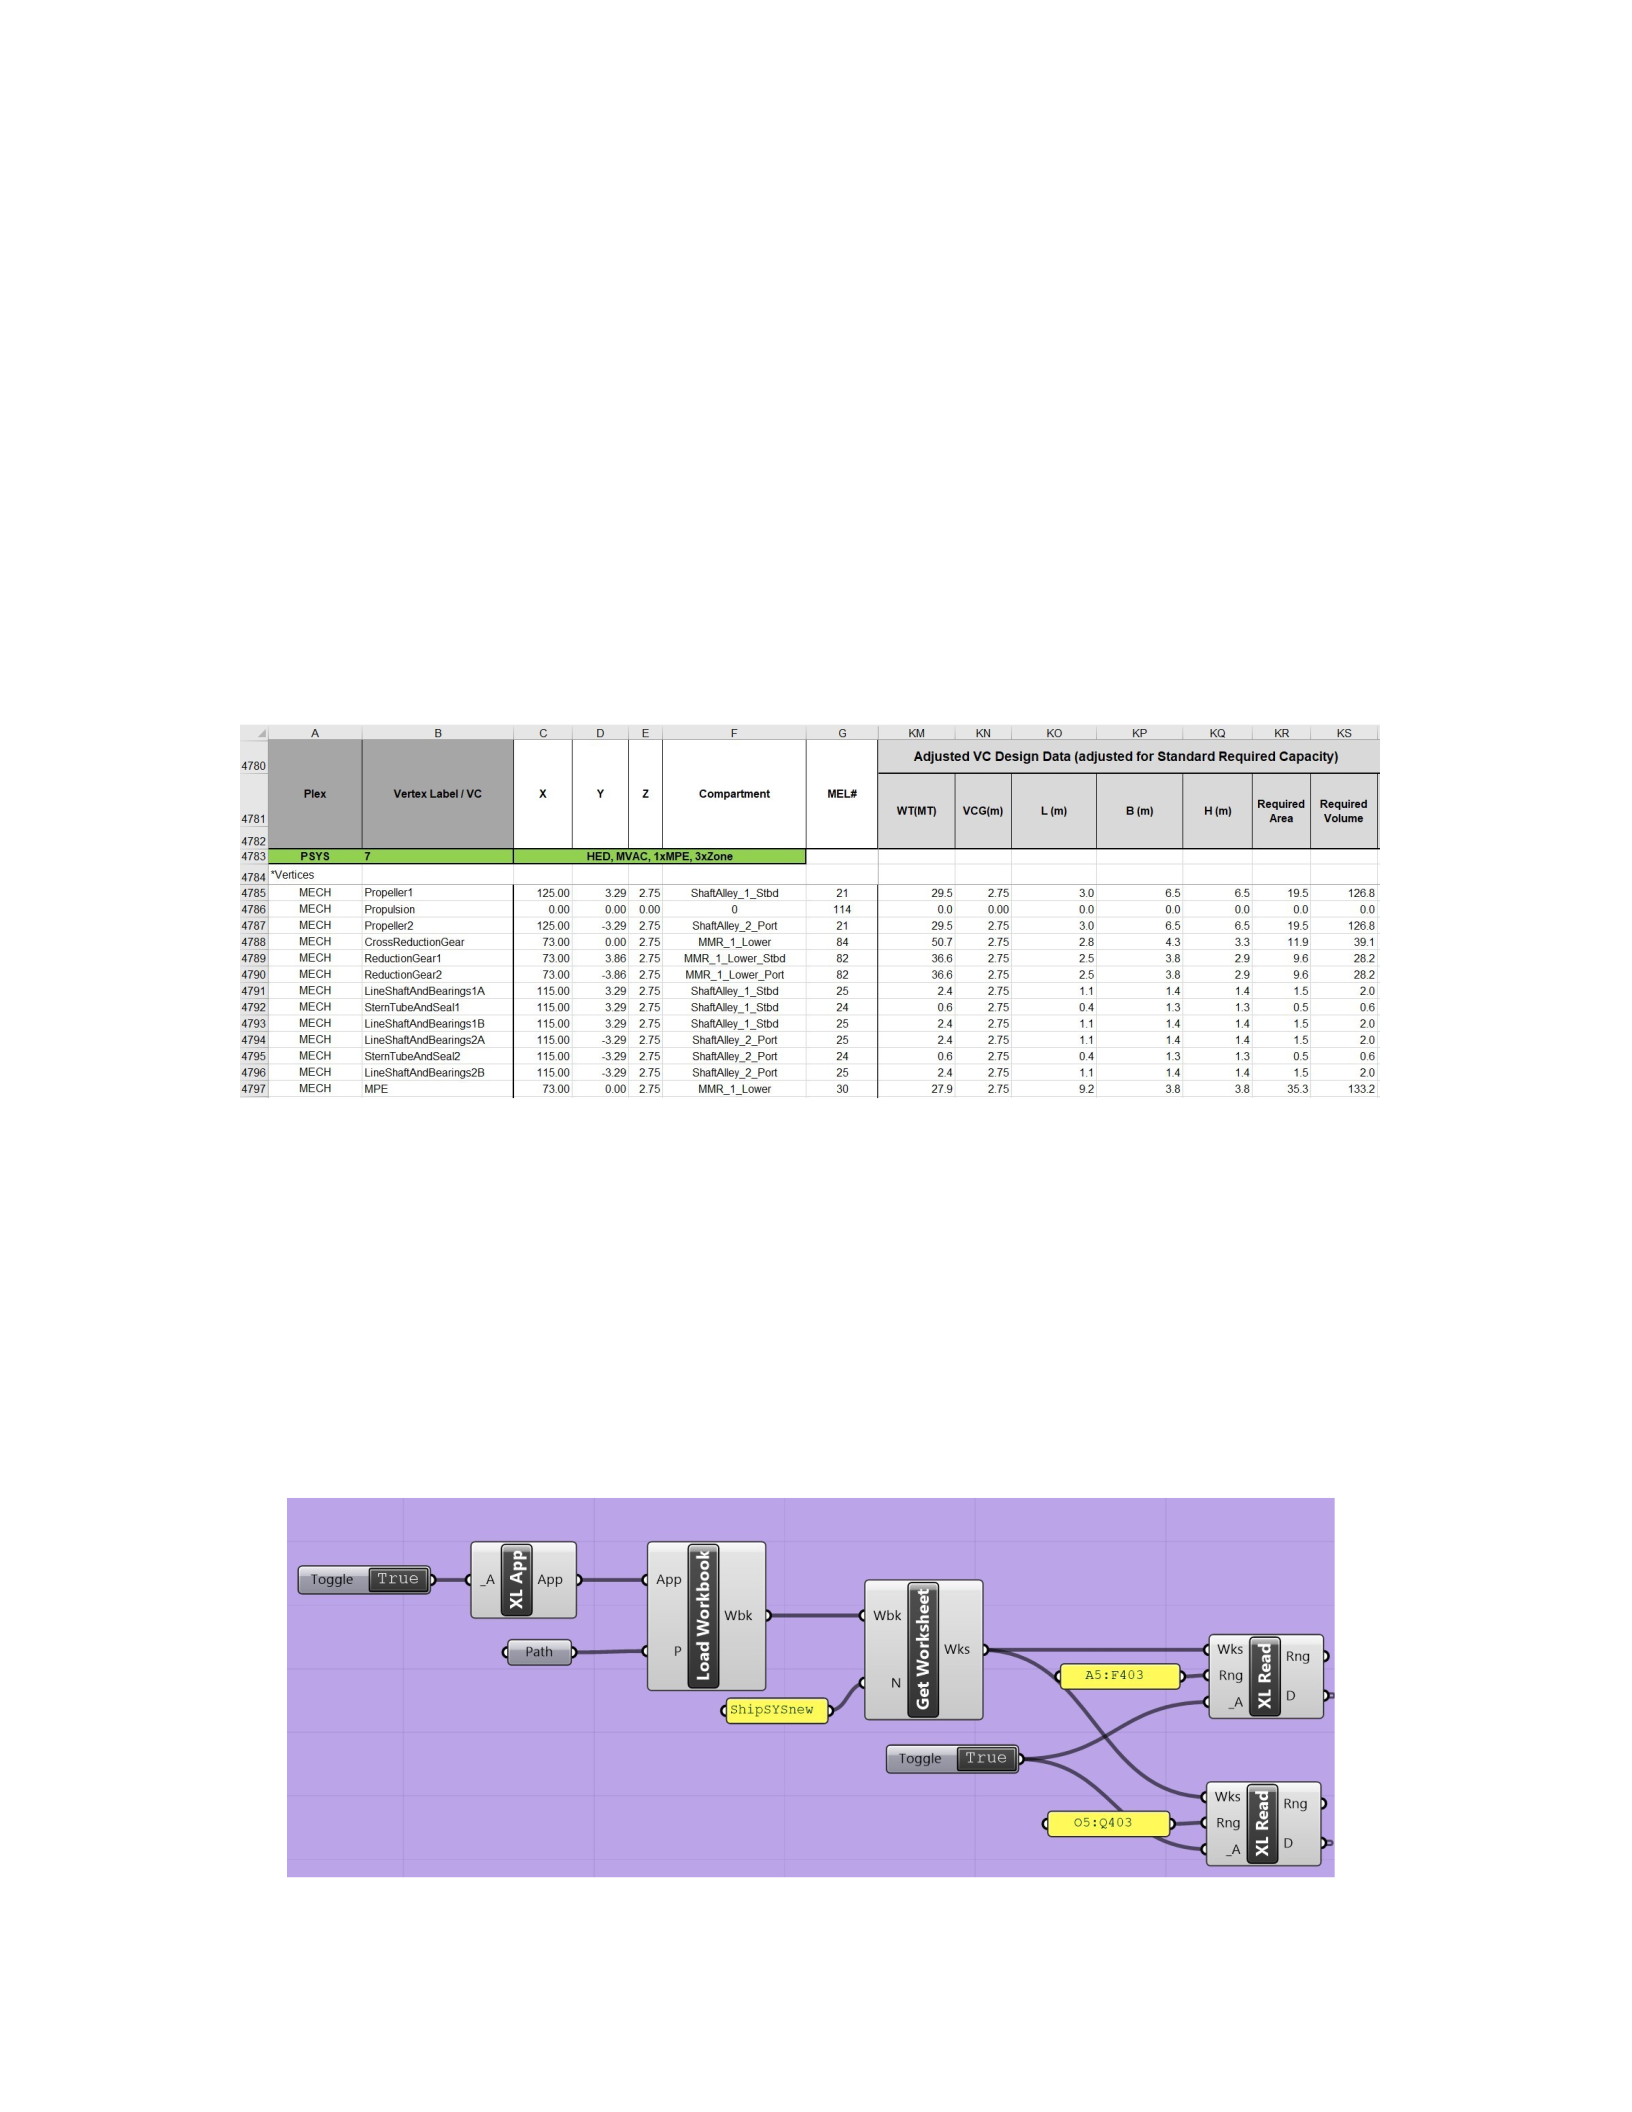
exact information in the desired SSM. The first imported dataset includes five columns of
information displayed in the ShipSYSnew tab section shown in the image below. Column
A, plex, indicates the VC subsystem, while column B Vertex Label/VC gives the VC
name. Columns C, D, and E, provide the X,Y,Z location of these individual VCs. These
locations
24
provided is the centroid of a specific subdivision block previously designed by the
VT research team and represents approximately where these components would be
found on the hull of the same size. The image below provides an example of SSM
data to be extracted that will provide the necessary location and dimensional
information for all VCs. Simultaneously, further data is imported from the
ShipSYSnew tab of SSM under the "Customized VC Design Data (adjusted to the
standard Required Capacity) section. This data represents specific size information
for each VC. The KO, KP, and KQ columns above represent the length, width, and
height of each VC.
Table 3.1: Data Extracted from Ship Synthesis Models
The Locust Code shown below in figure 3-4 is used to extract the VC information
shown in table 3.1. T hi s exa mpl e c lea rly i llu str a te s how G ra s sh opp e r
cod e a ppe a rs t o th e us e r as a c ode bo x w i th i nput s a nd ou tp u ts
con nec ted b y wi res a s d esc rib e d ear lie r.
25
Figure 3-4: Bumblebee2 encoding in a grasshopper that extracts the information of SSM VC
Now that the location and dimension information for the VC is imported into
Grasshopper, the data is then sorted into a data tree. Each branch of this data tree
directly correlates with the information columns extracted from ShipSYSnew's excel
worksheets in the synthesis model. These branches can now be sorted and placed as
input into a Grasshopper code shell that automatically creates a 3-dimensional
rectangular box Rhino object based on length, width, and height information as
shown in table 3.1.
Using the same data tree, the centroid of each subdivision block can be replicated
by a single point in Grasshopper using the "create point" command. These dots are
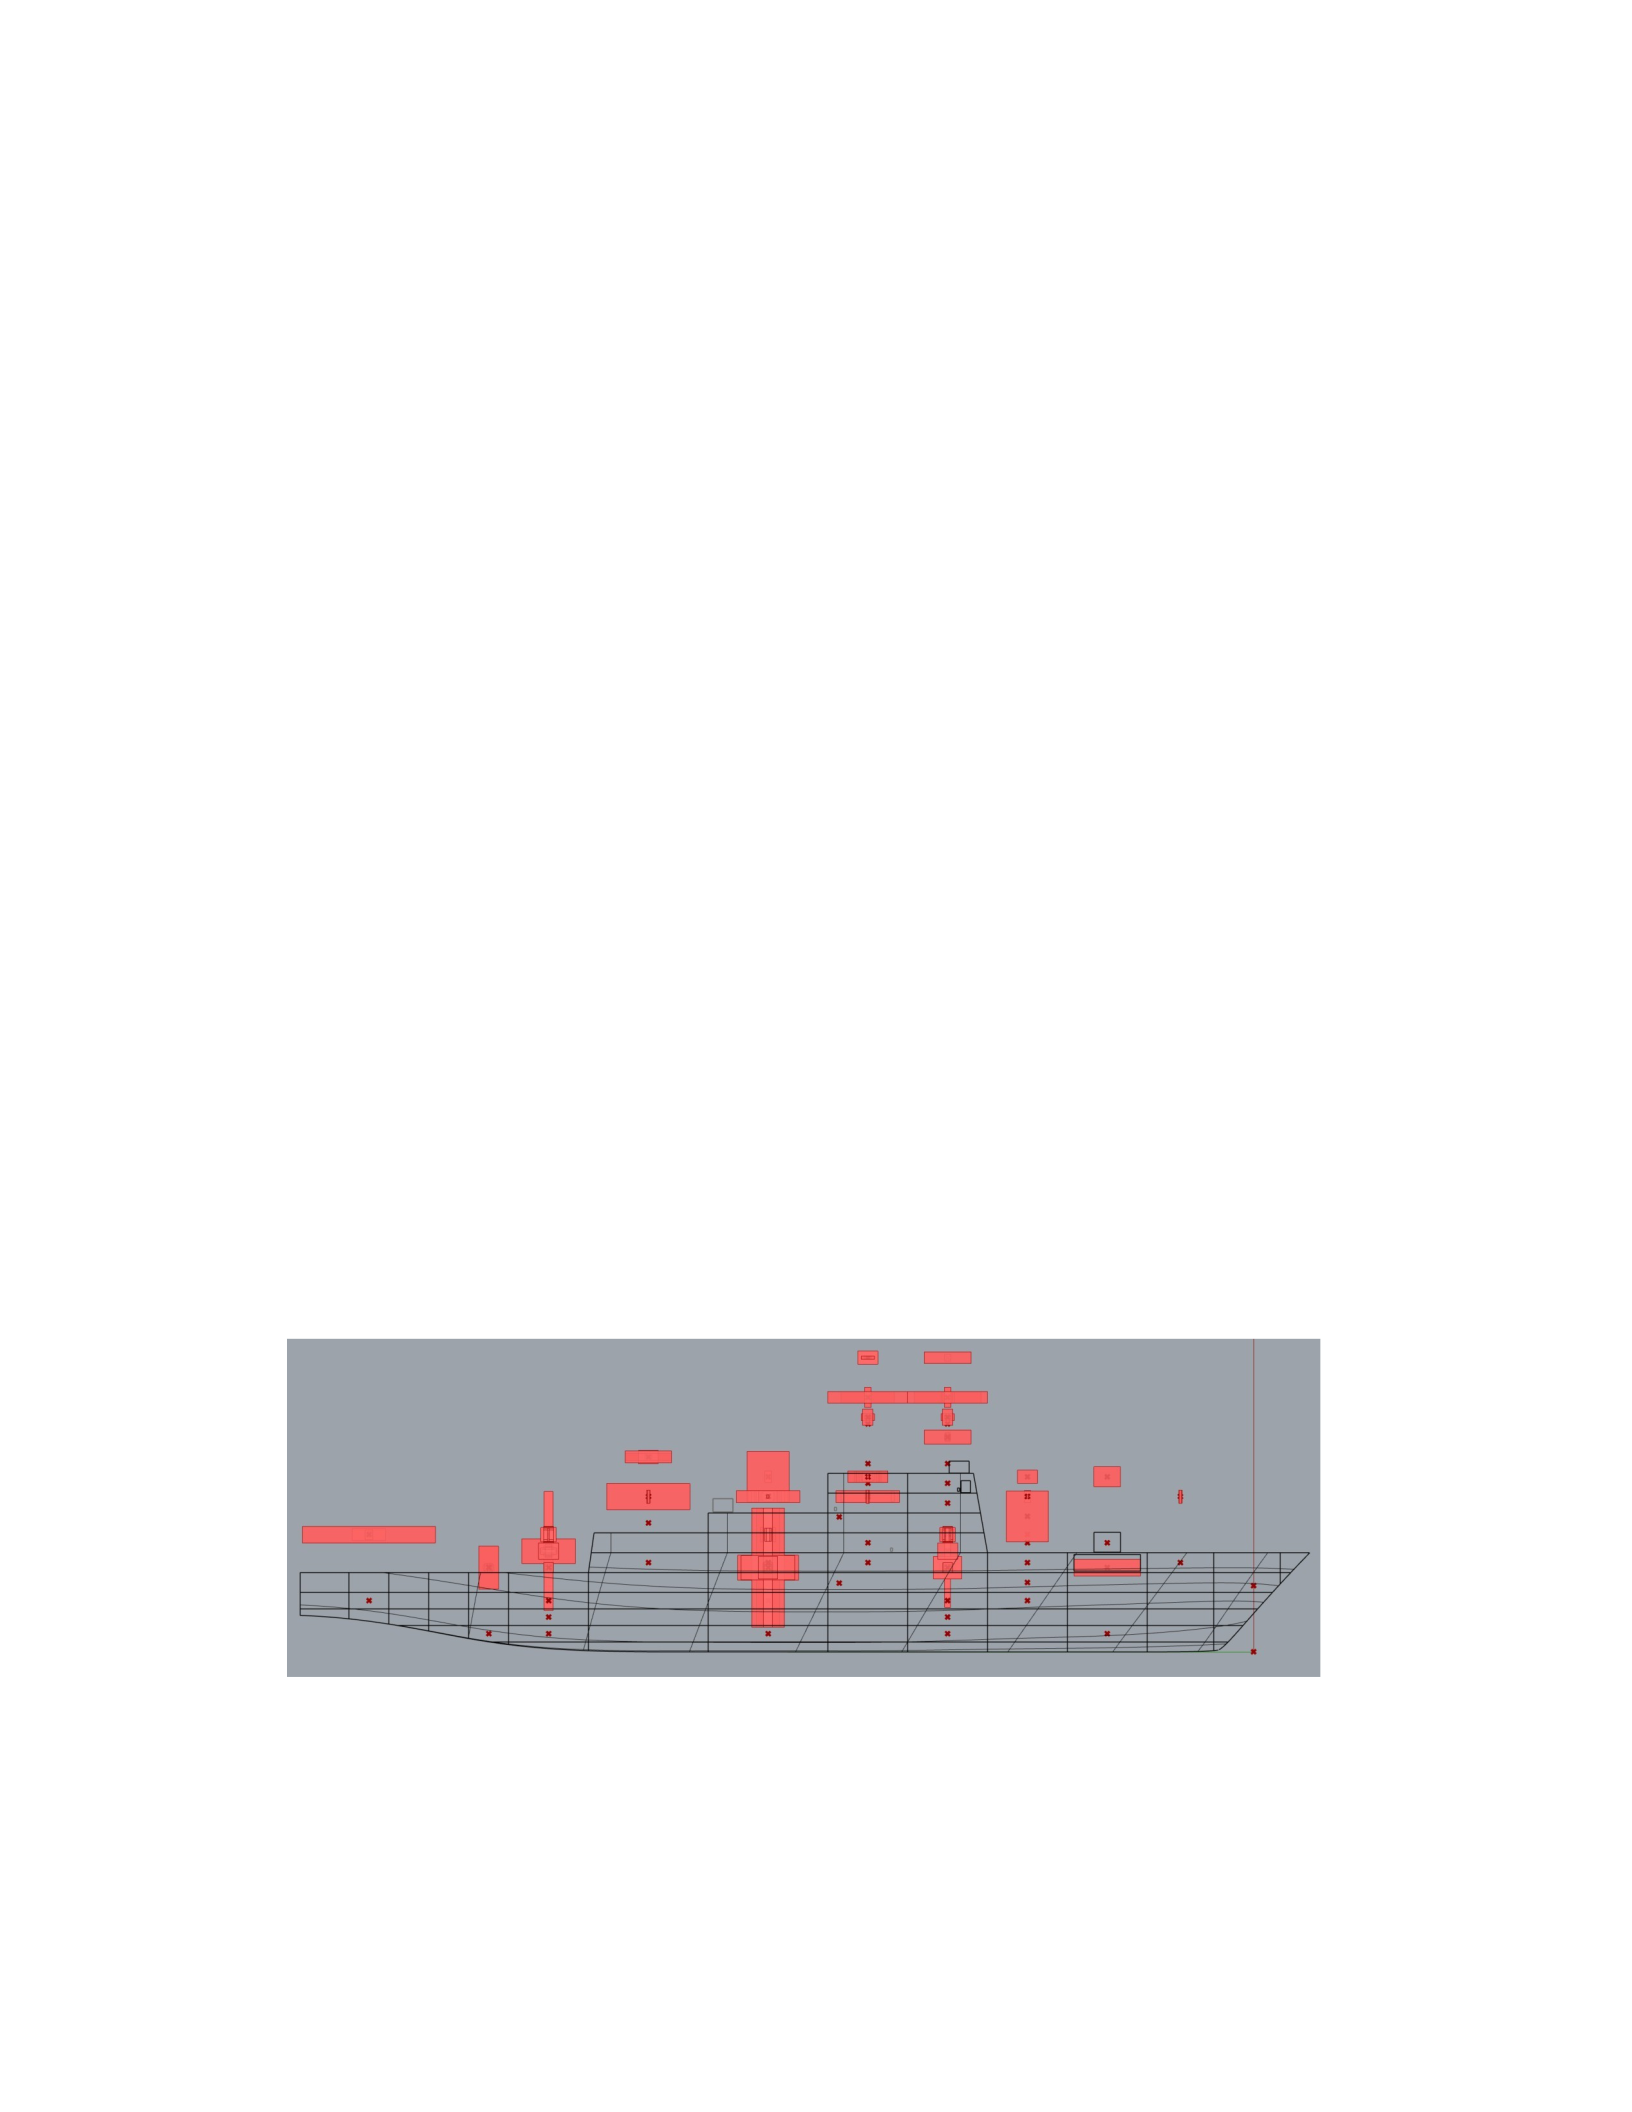
represented by a red cross in figure 3-5 below. The "move" command in Grasshop-per is
then used to move each VC to the appropriate subdivision block. This puts all VCs with the same
location information on top of each other in the approximate location where these VCs will actually
be on board. These locations are not exactly correlated with the hull as seen in figures 3-5 but are
almost correct. By completing this step, a Rhino object representing a VC with the
corresponding dimensions and location information is now visible inside the ship,
although the image is very crowded, with many VCs sharing the same location
information. These boxes have not been "baked" or actually made into Rhino but are
a red sketch of what the components in the model would look like if baked into
Rhino.
Figure 3-5: VC box and Subdivision Center block created in Grasshopper
After
this discovery was made, the decision was made to move forward with Grasshop-
per as the primary coding platform for this new initial setup design tool

26
as further research on Locust further increases the belief that it can be used to
achieve all goals.
3.3 Improving the Setup Tool
In order to create cleaner images and encourage an organized process for setting up
VCs in Rhino, it is necessary to organize and tidy up the number of Rhino objects
generated and placed in the same location. A straightforward solution to fix this
problem is to create a method to sort VCs into groups based on their subsystems, and
then place them into separate Rhino layers for each subsystem. This is achieved by
using the "plex" information in column A shown in table 3.1, which represents the
respective VC subsystems. By applying a data filter to the plex information, the
number of unique plexes can be determined which will then correspond to the
number of individual layers that need to be created. In this case, there are 18 unique
plex categories for more than 400 individual VCs.
The VC node/name label and assigned compartment found in column B and
column F of table 3.1 are separate branches of data in Grasshopper, respectively. These two
branches are combined, and attached to each VC correlate as a property of the Rhinoceros
object. Now that the VC plex, node/compartment information, dimensions, and locations are all
known, they can be inserted into Rhino as "attributes" using the Grasshopper Elefront plug-in
that must be downloaded and added to Grasshopper to complete this task. This bake function
permanently creates a box in Rhino
that is now free to move and also creates a number of
individual layers determined
by the number of unique plexes in the VC list. Next,
the VCs are then sorted into the corresponding layers, and the layers are colored
to distinguish the components from those in other plexes. Examples of the
various layers with VC baked into the Rhino model are provided below.
27
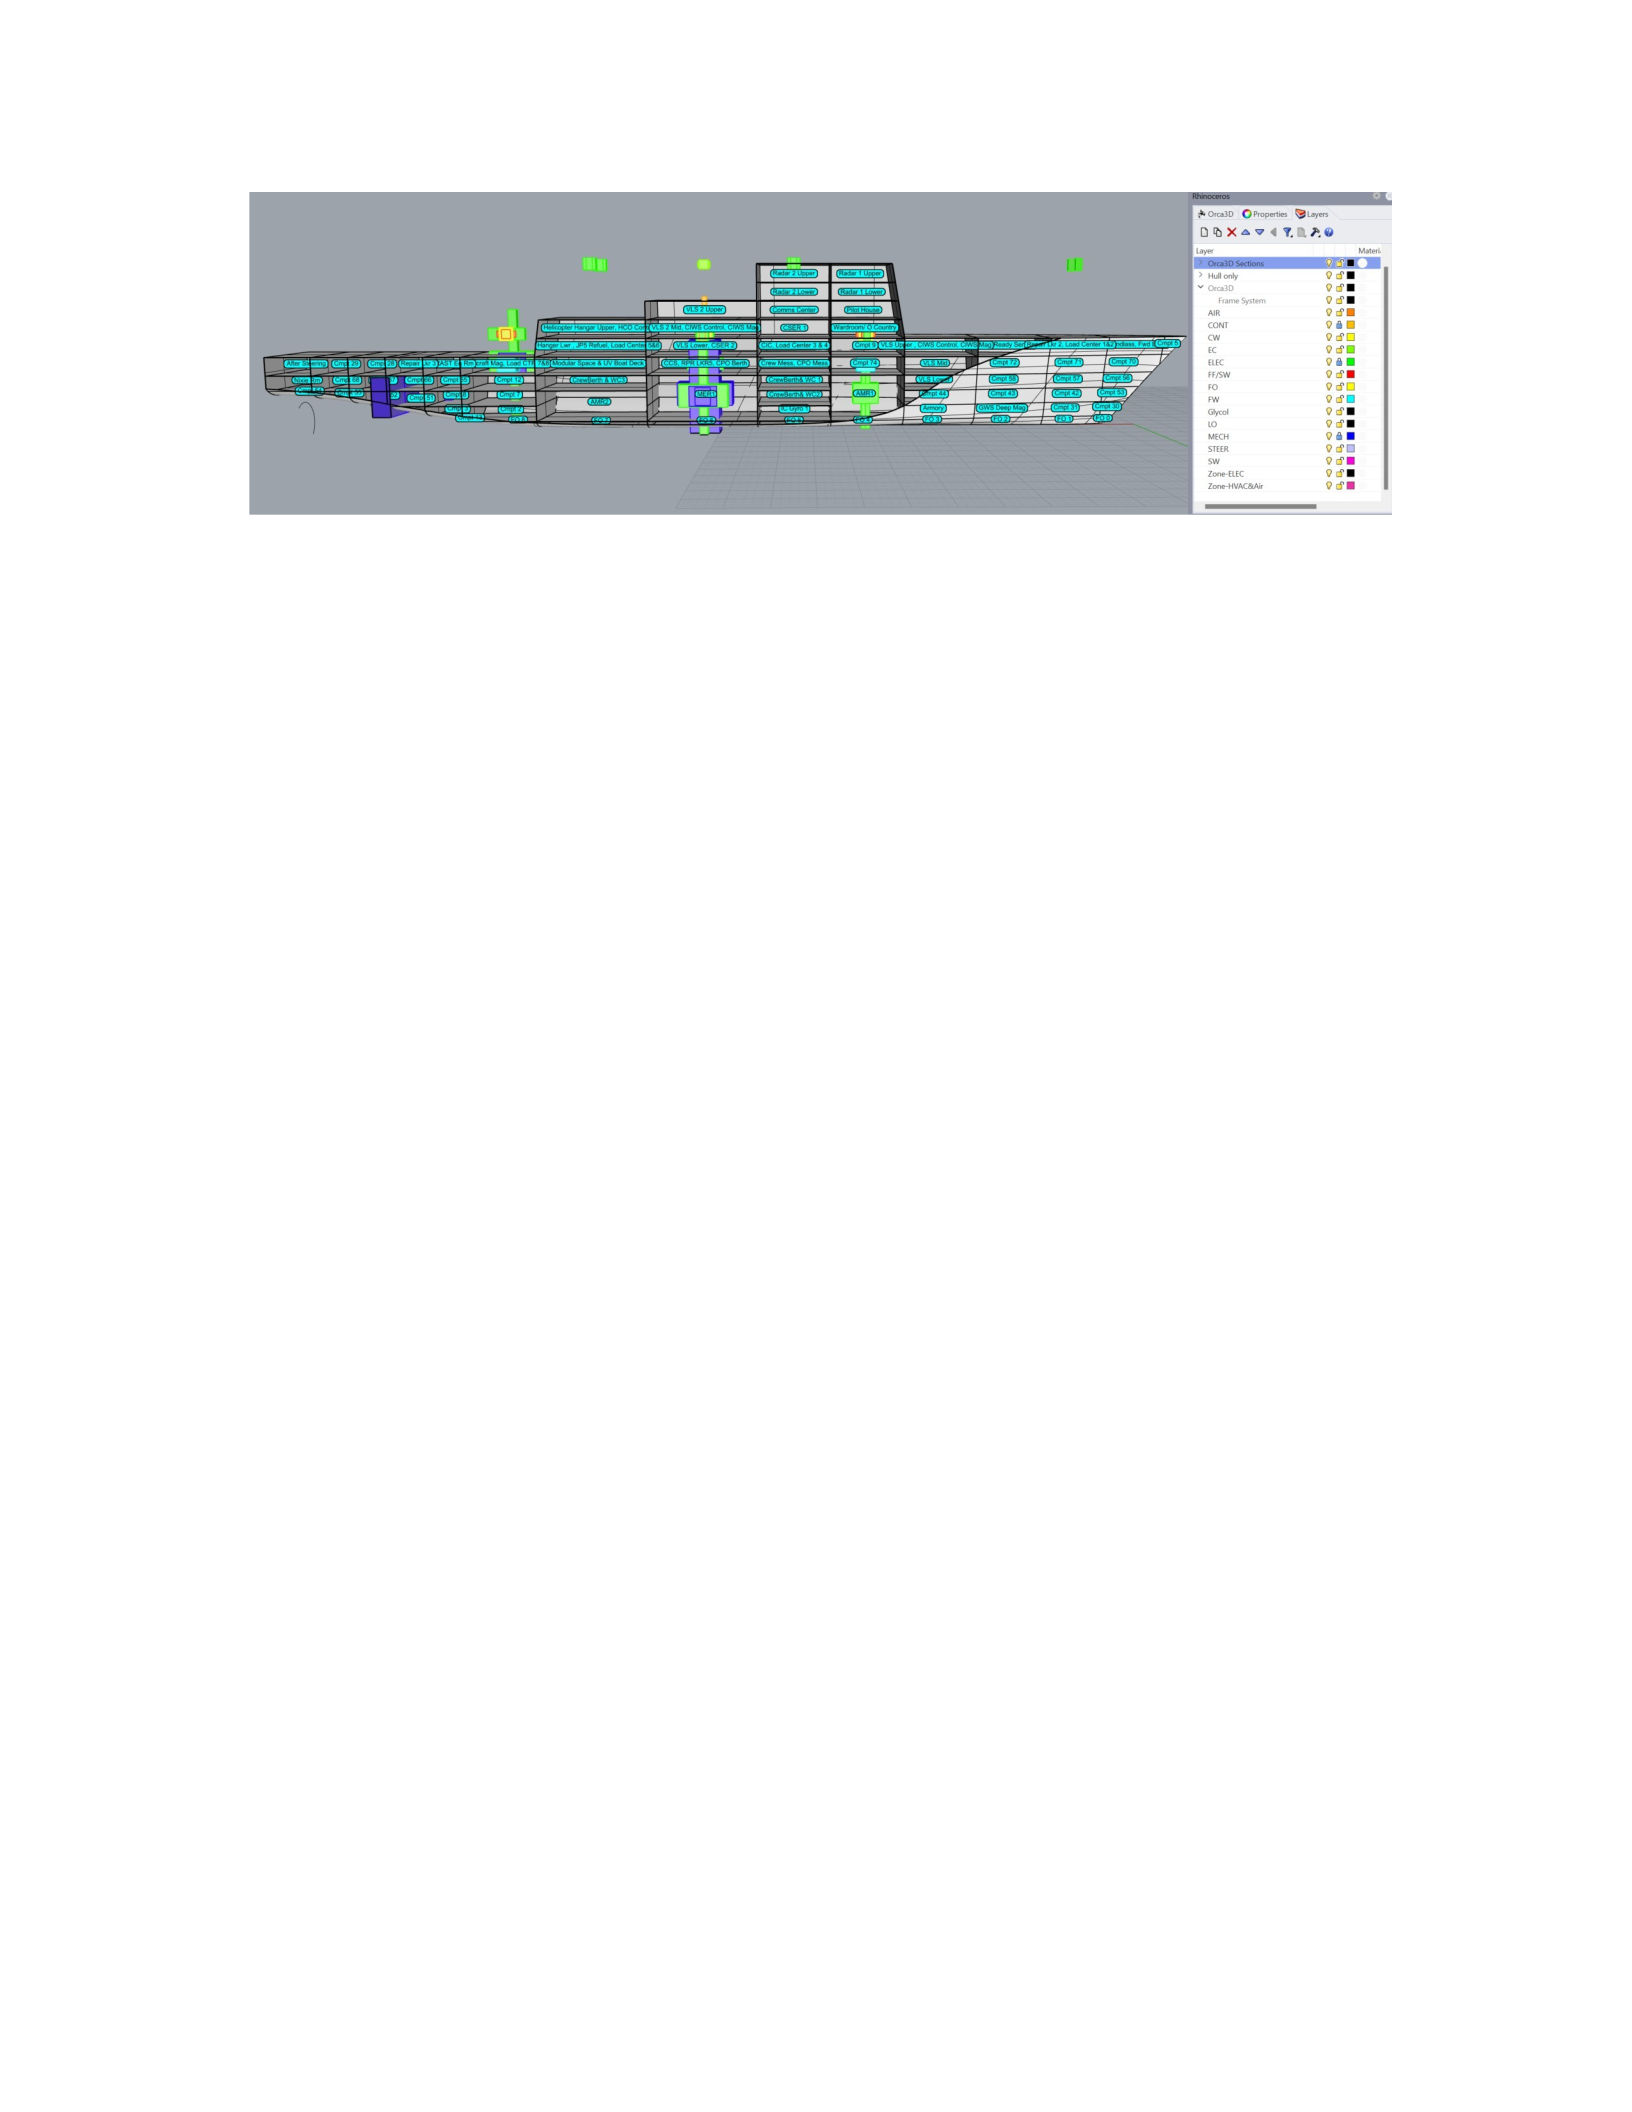
Figure 3-6: VC Made from Locusts and Arranged into Layers
As shown above in figures 3-6, the image was very crowded at first with many
VCs imported on top of each other. The name of the compartment generated by Orca
V2.5 is increasingly crowding the image. The designer can also clearly see that the
VCs need to be moved to the appropriate location because some are outside the ship
because the VCs are placed in the centroid of the subdivision blocks, which roughly
represent their actual location inside the ship.
The obvious advantage of this process is that with each group of vital components
organized into layers, the active layers can remain visible while others can be hidden
to greatly reduce clutter in Rhino 3d's view-ports and make the process of manually
arranging components much more efficient. When a user selects an individual VC in
Rhino, the object's properties can also be viewed under the "properties" menu. This
property contains the VC name and the assigned compartment. When the Large VC
located in the main chamber such as a propulsion engine is set up, a system known to
be associated with an engine such as a fuel oil pump can be brought forward by
turning on the fuel oil layer (FO) and locking the MECH layer. Now all FO VCs can
be seen and arranged precisely around the machine without making any unwanted
changes to the MECH layer. By locking the finished layer, the error of accidentally
moving components can be greatly reduced. It is up to the designer to determine the
most effective method for setting up VCs within their respective engineering spaces,
although it is advisable to start with the most complex and/or physically largest
systems.
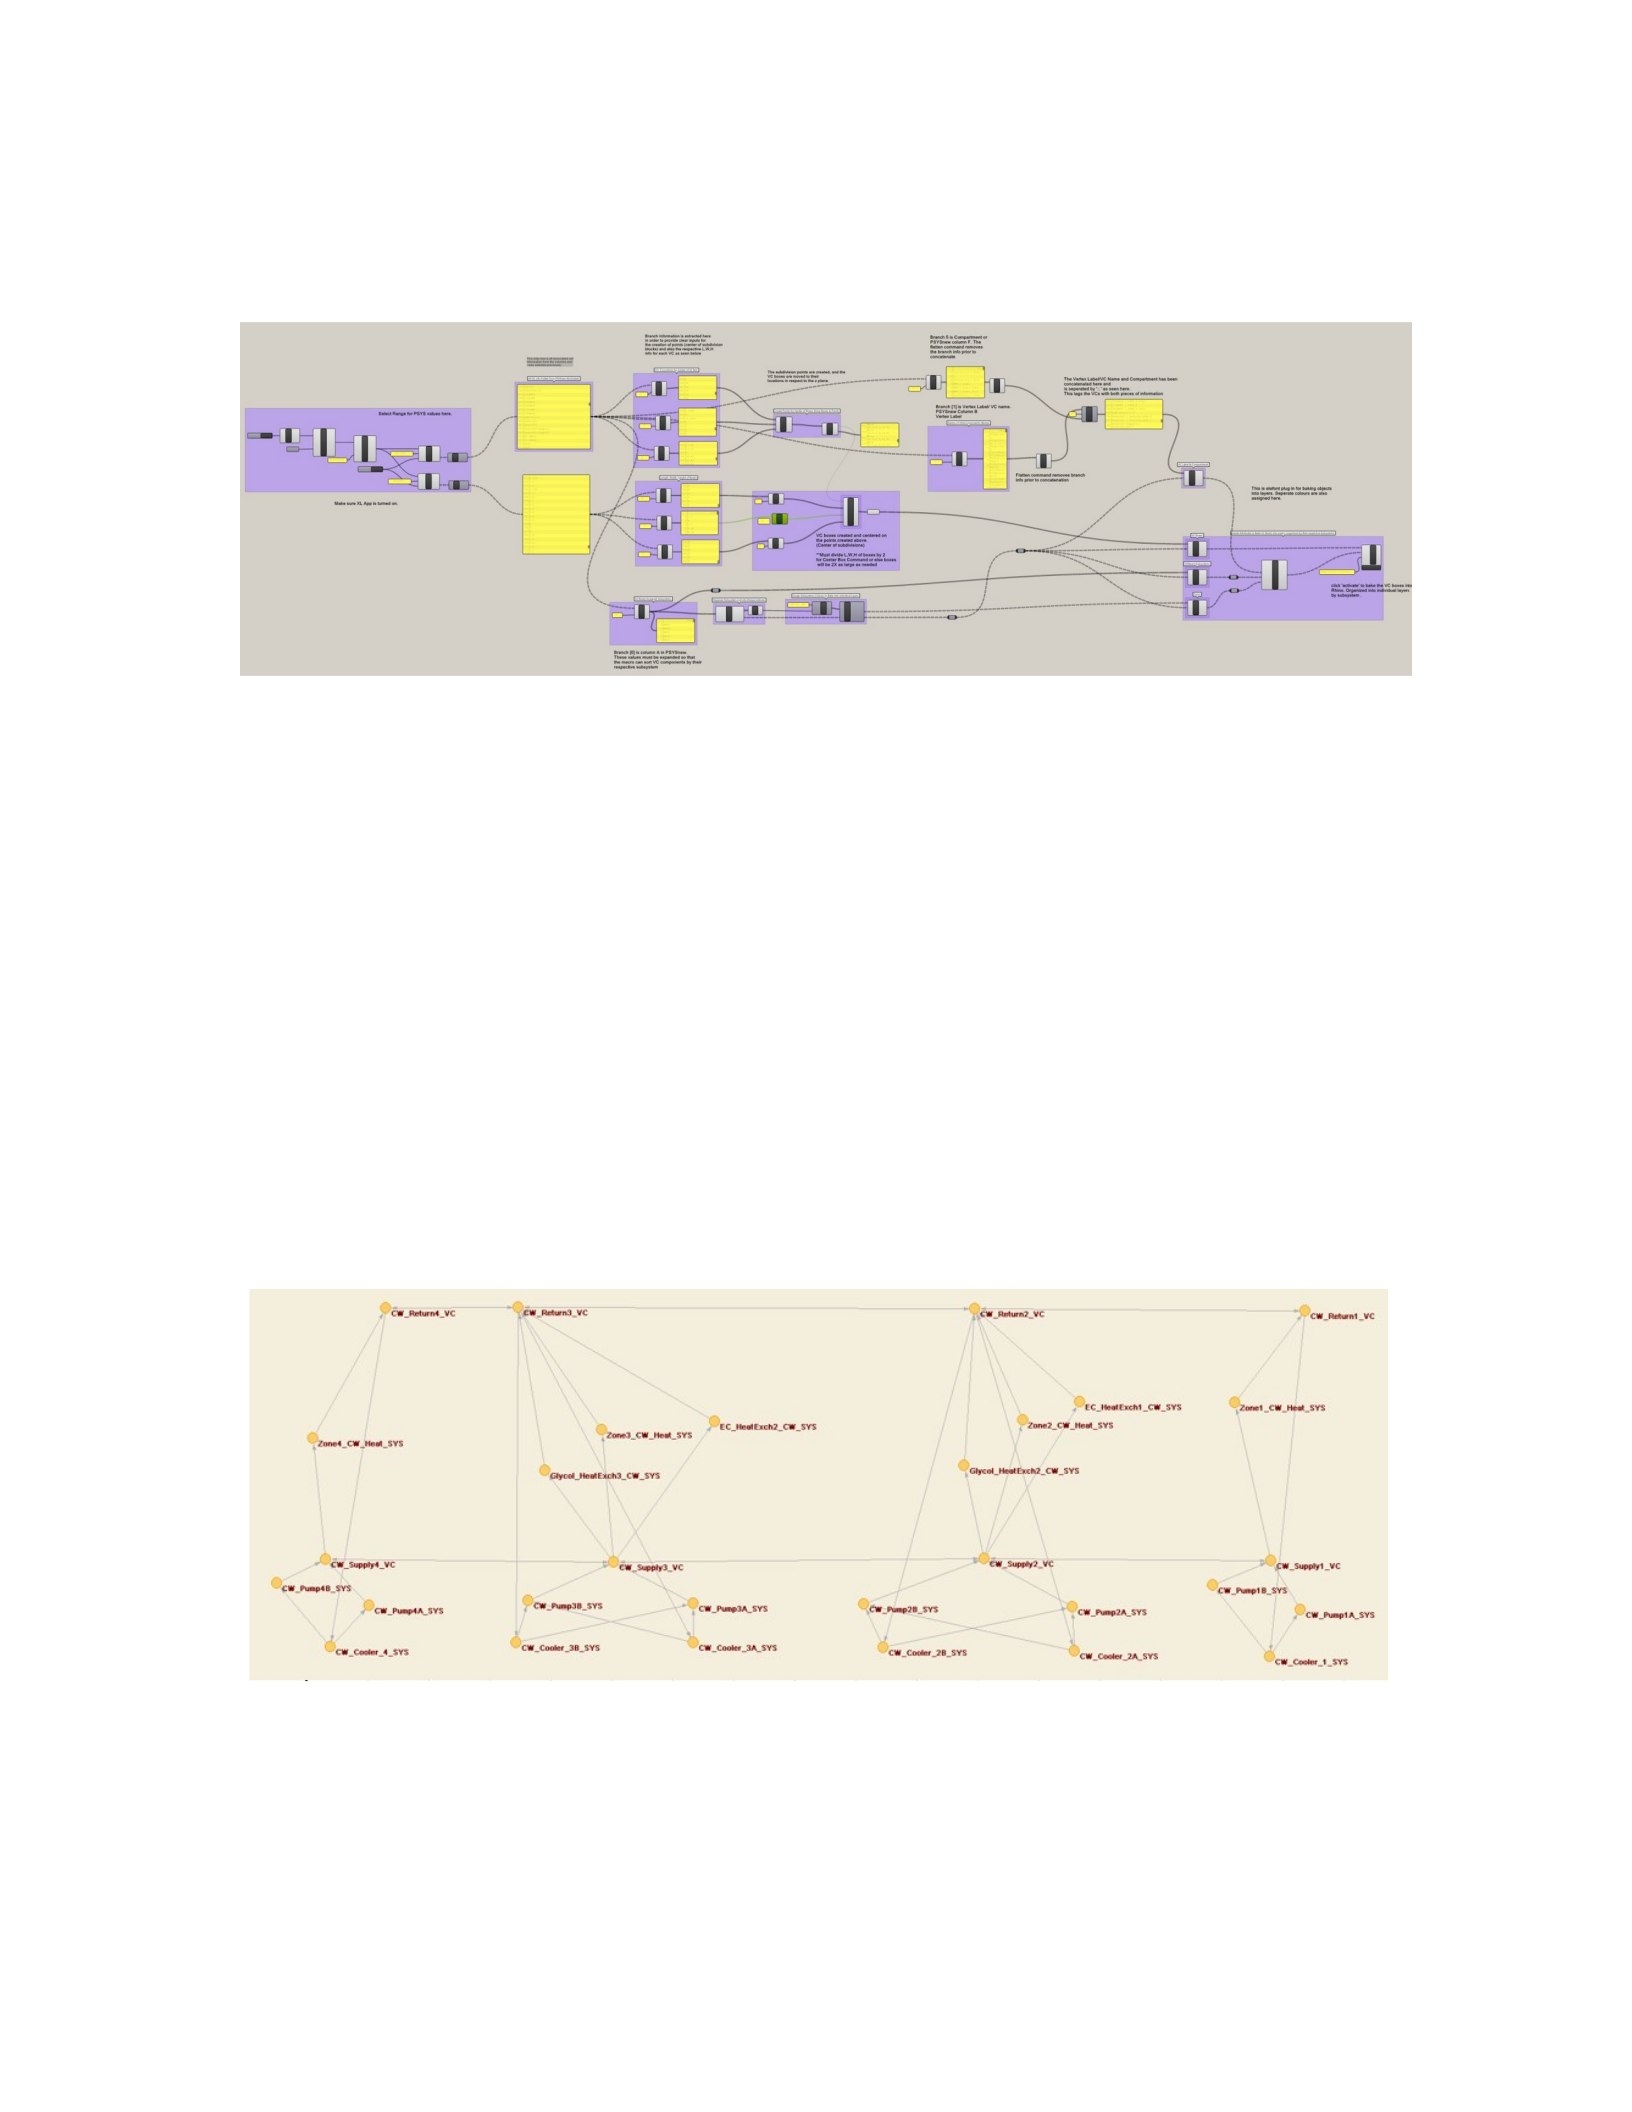
Finished coding view for the initial setup tool in Grasshop-
28
per is shown below. Further technical descriptions of this code can be found in Ap-
pendix A.
Figure 3-7: Locust Code for the Initial Setup Tool
3.3.1 Added Connectivity between VCs in Grasshopper
Vital Components are generally connected by some physical part be it a conduit,
pipe, cable, conduit, or any other form. It is estimated that if this physical
connectivity can be replicated in the initial setup tool, then the designer can more
accurately place the VC in the correct location that will align the physical
architecture of the system with the logical architecture found in the nodal diagram as
shown below in figure 3-9.
Figure 3-8: Logical Architecture for Chilled Water System
This image shows the logical architectural complexity for a chilled water system.
If the line between the VCs shown in the image can be replicated in real
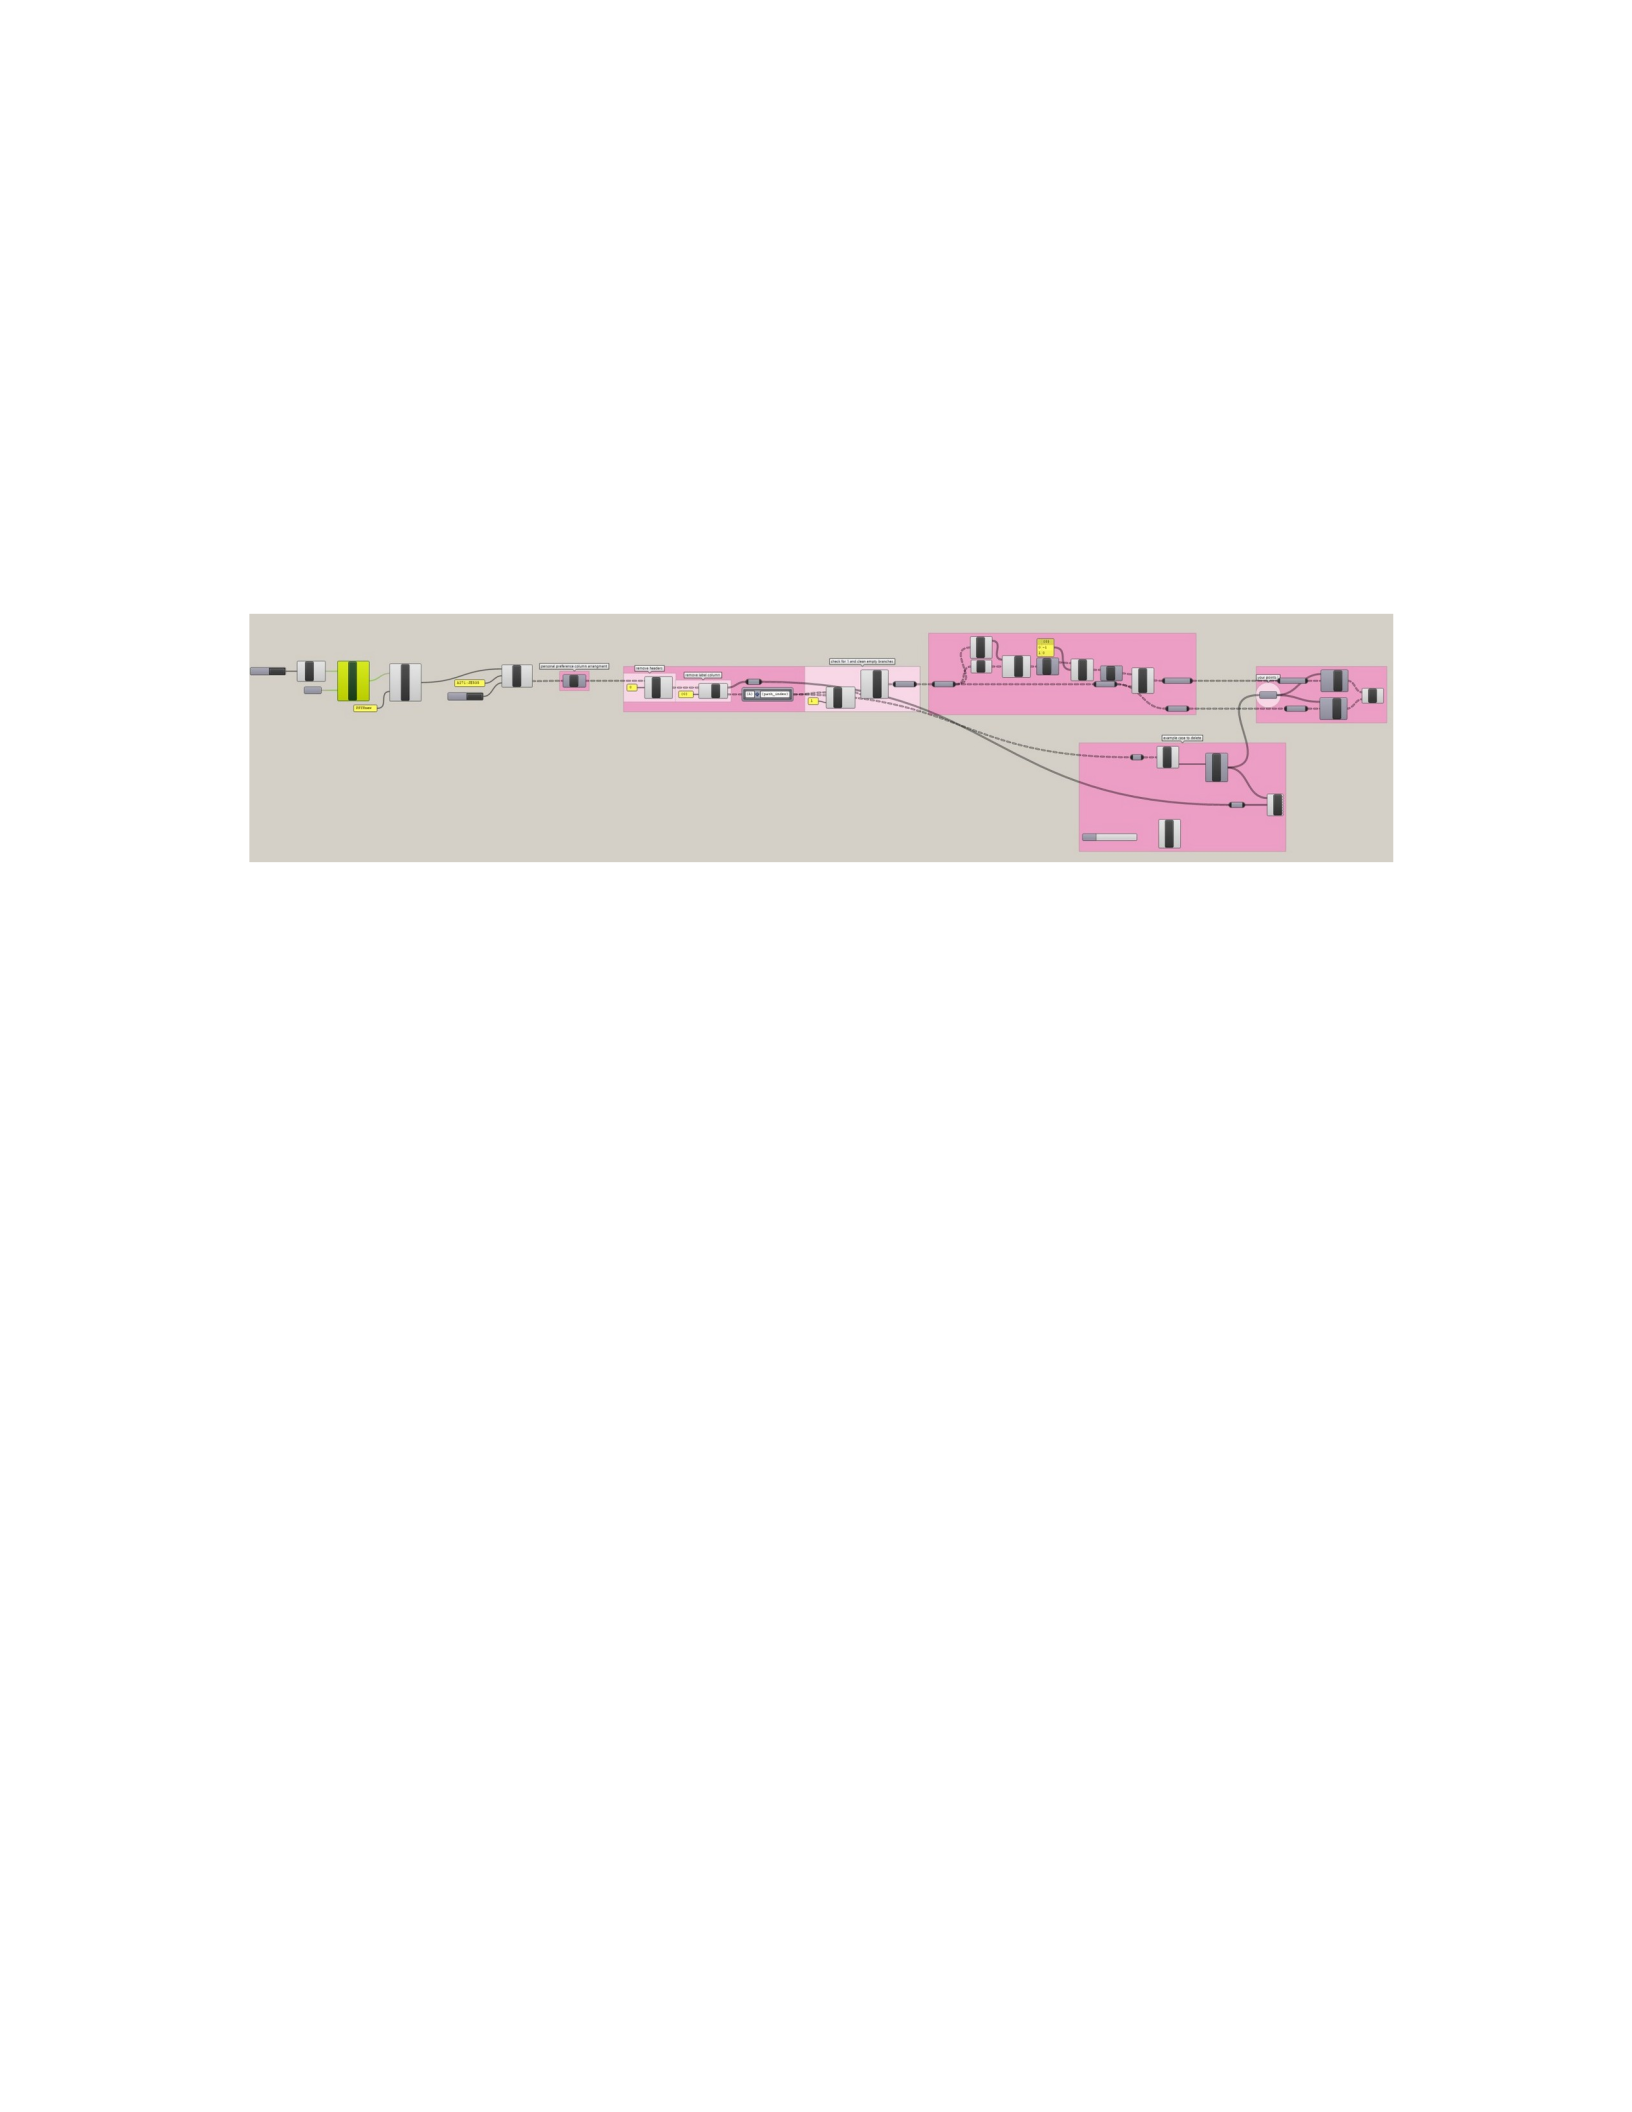
29
Rhinoceros, then the nodal diagram will be a stronger reference and the designer can
be more confident that the VC is in the correct orientation with respect to other VCs
in the same subsystem. The proximity matrix is present in SSM, which
mathematically holds the connectivity between VCs. A successful attempt was made
to read this proximity matrix, import the related connectivity information into
Grasshopper, and then create a line between the VCs to visually indicate the
connectivity in Rhino according to the logical architecture of the system.
Figure 3-9: Locust Code for VC Connectivity
The coding for this part of the tool is more complex than what is required for the
initial setup tool and will only be briefly described in this section. Although this code
has proven to run successfully in Grasshopper and interact with Rhino, there are two
critical problems with achieving the goal of showing connections between VCs. The
first problem is that some VC dimension values are equal to zero in SSM. It is
filtered from the initial setting tool as a zero value, however the VC is still included
in the proximity matrix and therefore the connectivity line is drawn to the VC which
has the zero dimension and is therefore invisible. This creates many connectivity
nodes inside the ship that sometimes have multiple connectivity paths that end up
being invisible VCs. Further complicating this issue is that the original configuration
of SSM has embedded zone locations for certain systems that do not have VCs
assigned to them. Figure 3-10 below shows the current state of connectivity in
Grasshopper. The hull has been concealed from this view to tidy up the port of view
of the Rhino.
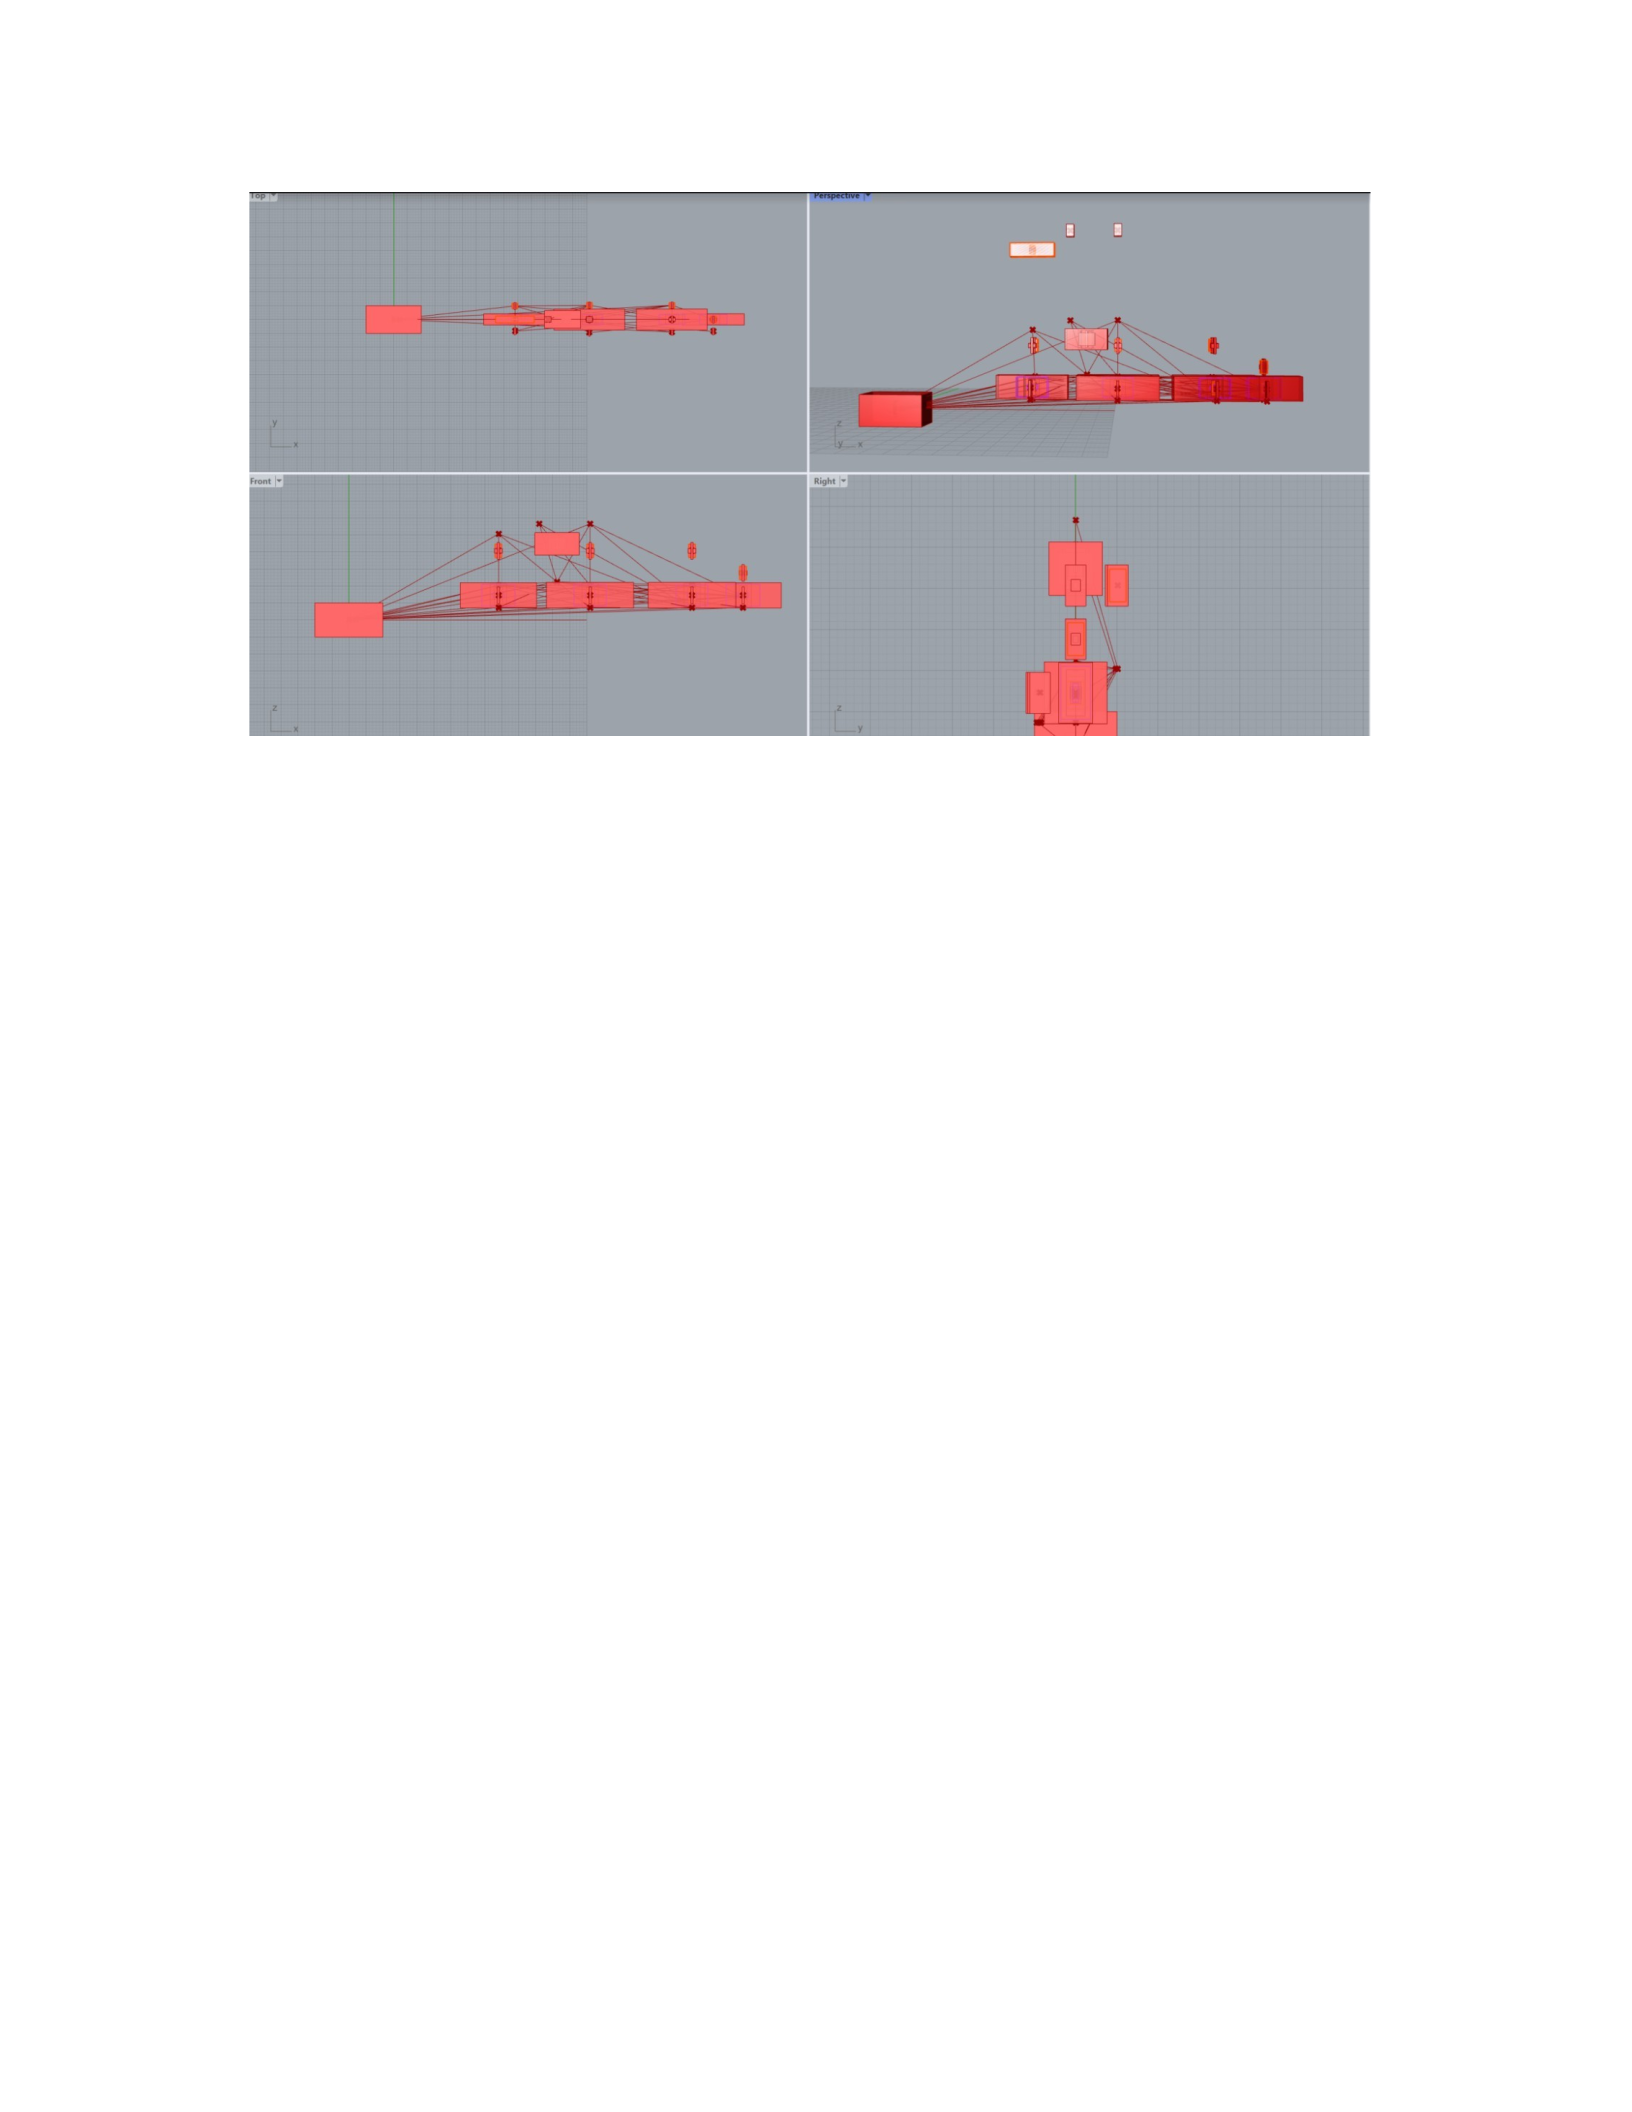
30
Figure 3-10: VC Connectivity Path
This problem is intended to be fixed by a separate research team that is currently
in the process of overhauling the proximity matrix format. The second problem faced
in the design of VC connectivity tools is that there is no method to connect
connectivity paths to individual VCs found. This creates problems when VCs are
moved and their associated connectivity paths don't follow them. The immediate
solution to this problem is to automatically pair the connectivity path with the
centroid of each Rhino VC object. That way the connectivity path will move with the
centroid of each VC object, and the connectivity line that crosses it can indicate that
the arrangement is potentially inconsistent with the logical architecture of the system.
A further advantage is that it automatically places these stripes in an organized Rhino
layer that can help clean the Rhino display ports while actively working to set up the
system. Rarely does a system's physical architecture reflect the exact pattern of its
logical architecture, although this connectivity path can show further learning points
during the initial setup process by highlighting the complexity of routing connections
between components in order for the system to operate in very close proximity to
each other. Further research and design work is required to complete this part of the
initial setup tool in Grasshopper.

31
Article 4
Case Study for U.S. Navy Fleet
The conceptual design of the new U.S. Navy Fleet (FFGVT-2022) was completed
using the C&RE total ship synthesis process to provide a new platform to test
common setup tools at Grasshopper and support other ongoing research projects at
Virginia Tech. This chapter contains an edited description of the FFGVT design and
how the initial setup tool is used to verify the feasibility of the design. The following
description of FFGVT-2022 is taken from its ICD, the full ICD can be found in
Appendix B.
FFGVT will be a medium-sized surface combatant capable of carrying out
homeland strength and defense, and Intelligence, Surveillance, and Reconnaissance
(ISR). It is expected that the FFGVT will be able to operate independently, with the
Surface Action Group, with the Carrier Combat Group (CBG), and to support the
Expeditionary Strike Group (Amphibious Force) providing AAW, ASUW, and ASW
support. The Surface Action Group (SAG) will conduct a variety of EW and ISR
missions in addition to providing their own AAW, ASUW, and ASW defenses. The
ISR's mission will include the use of autonomous air, surface and subsurface
vehicles, and LAMPS.
The initial size calculation creates the destination range and threshold for the
physical size of the FFGVT as well as the initial estimate of the propulsion and
electrical power required.
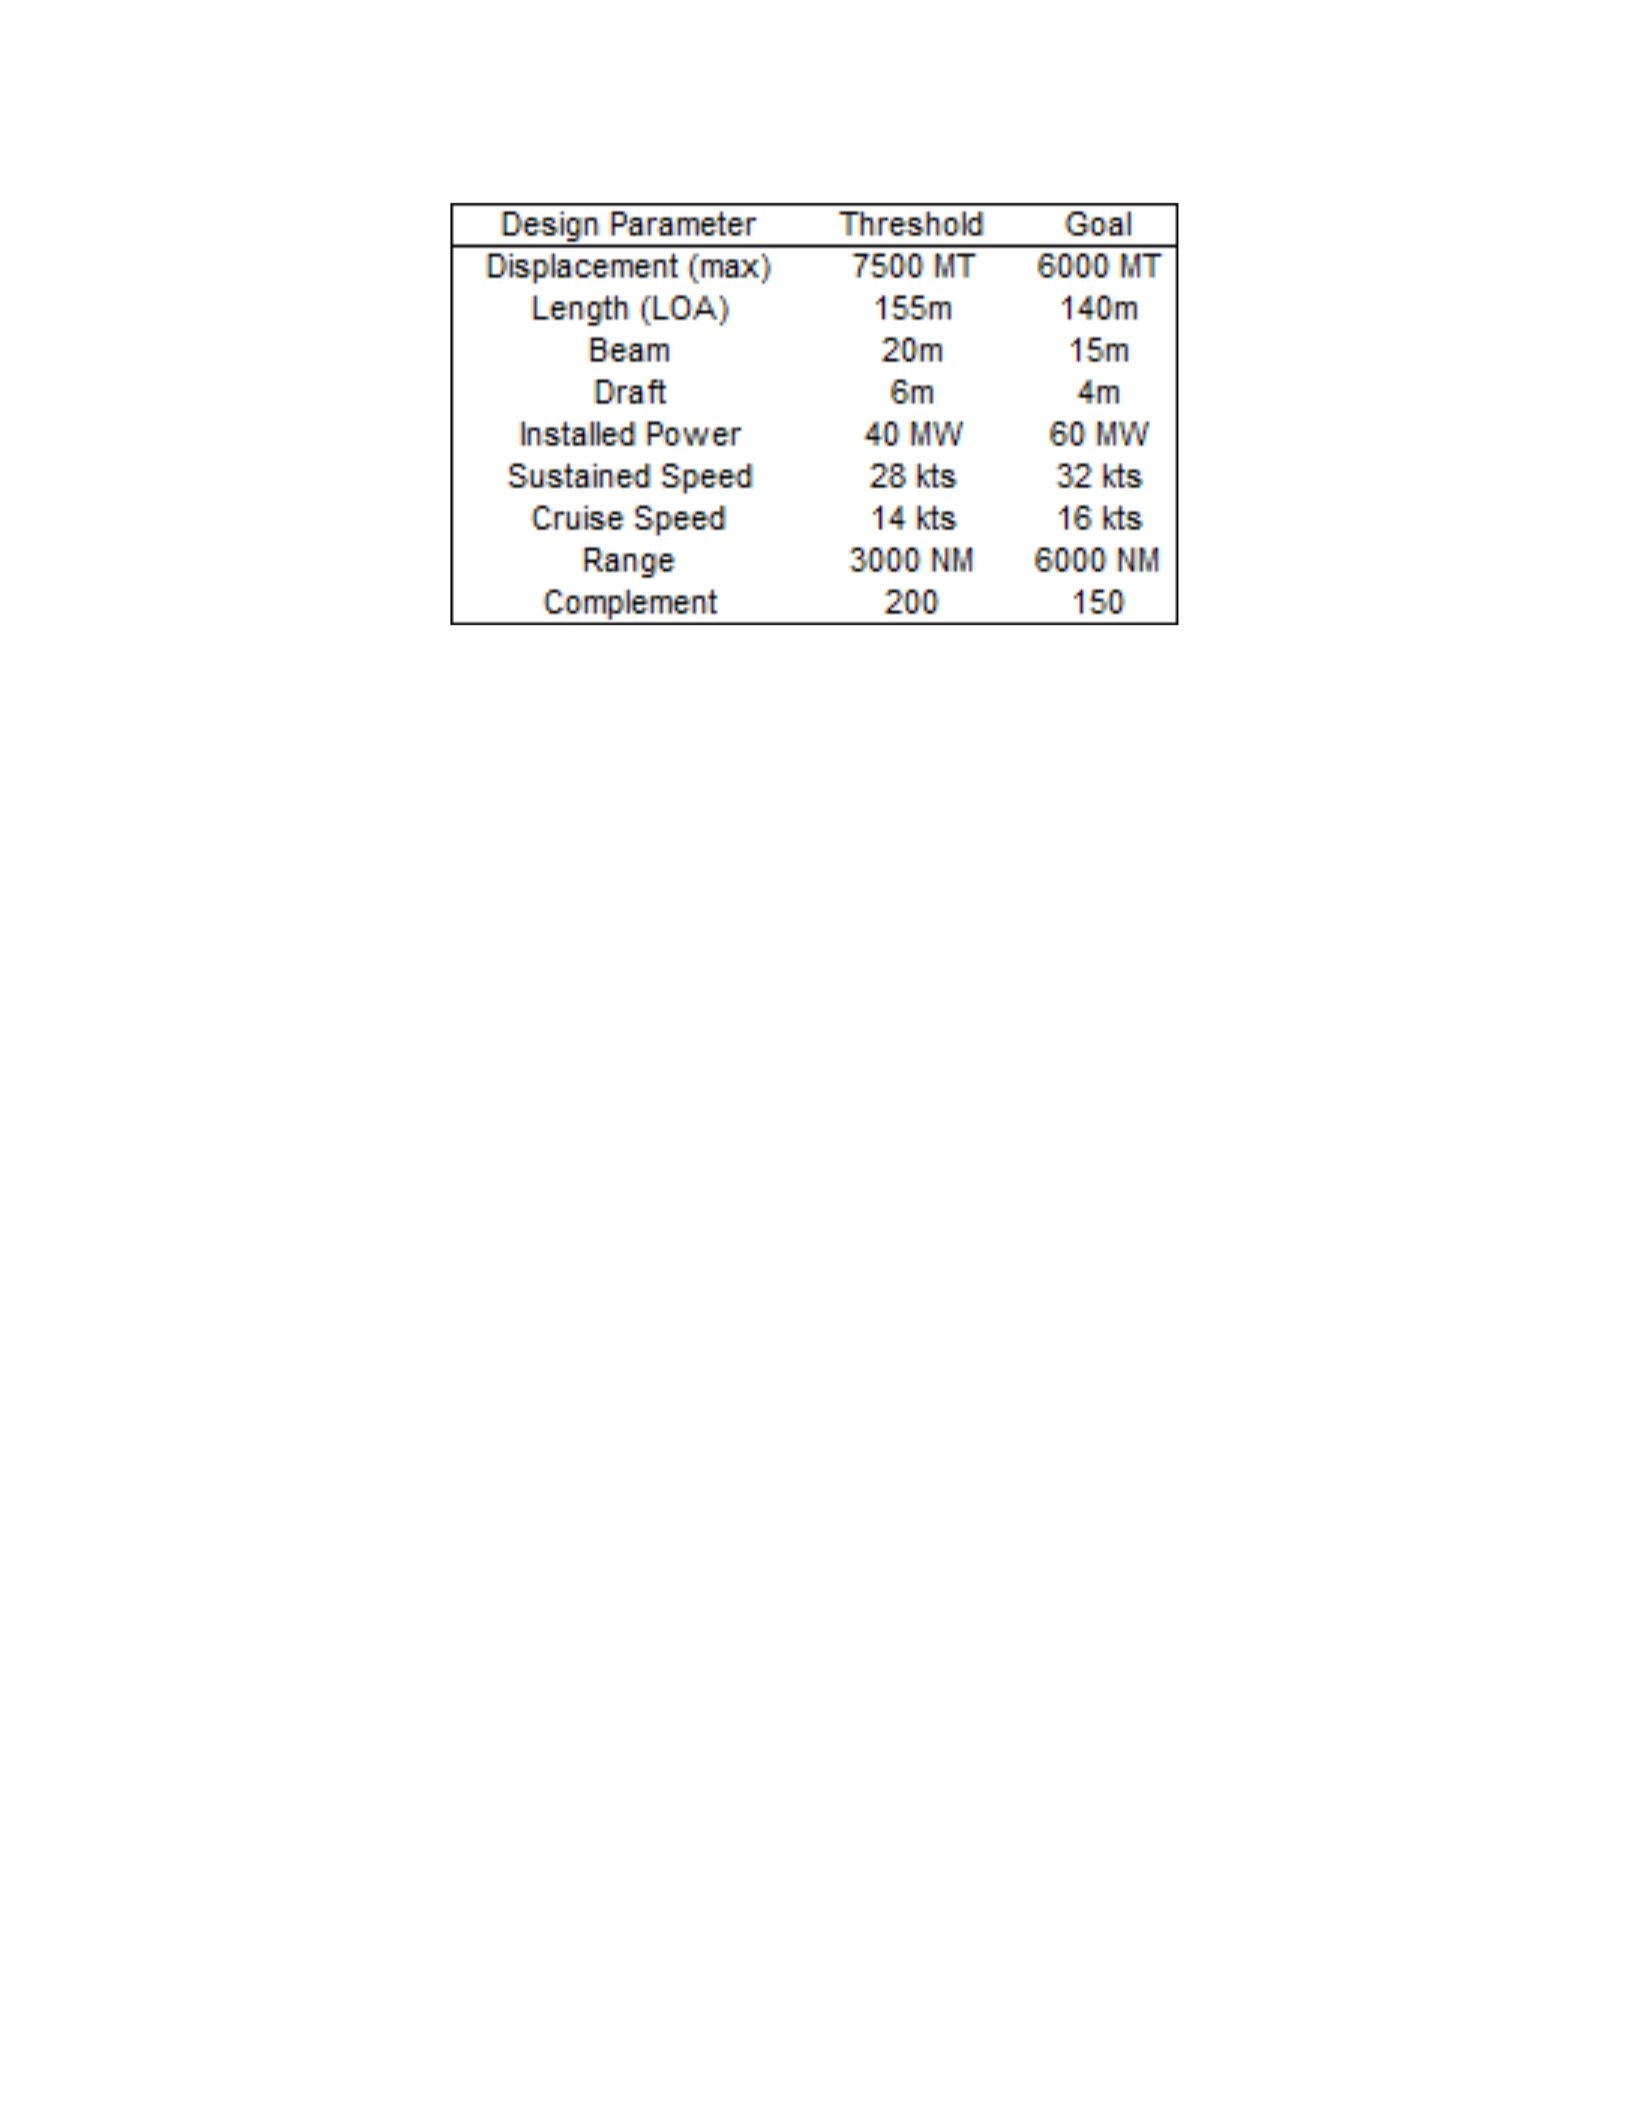
32
Table 4.1: FFGVT Initial Size
The design parameters shown above classify FFGVT as a medium-sized surface
combatant according to US Navy standards. In order to achieve all desired mission
areas, threshold values and objectives for operational and combat systems, combat
capabilities are created and shown in table 4.2.
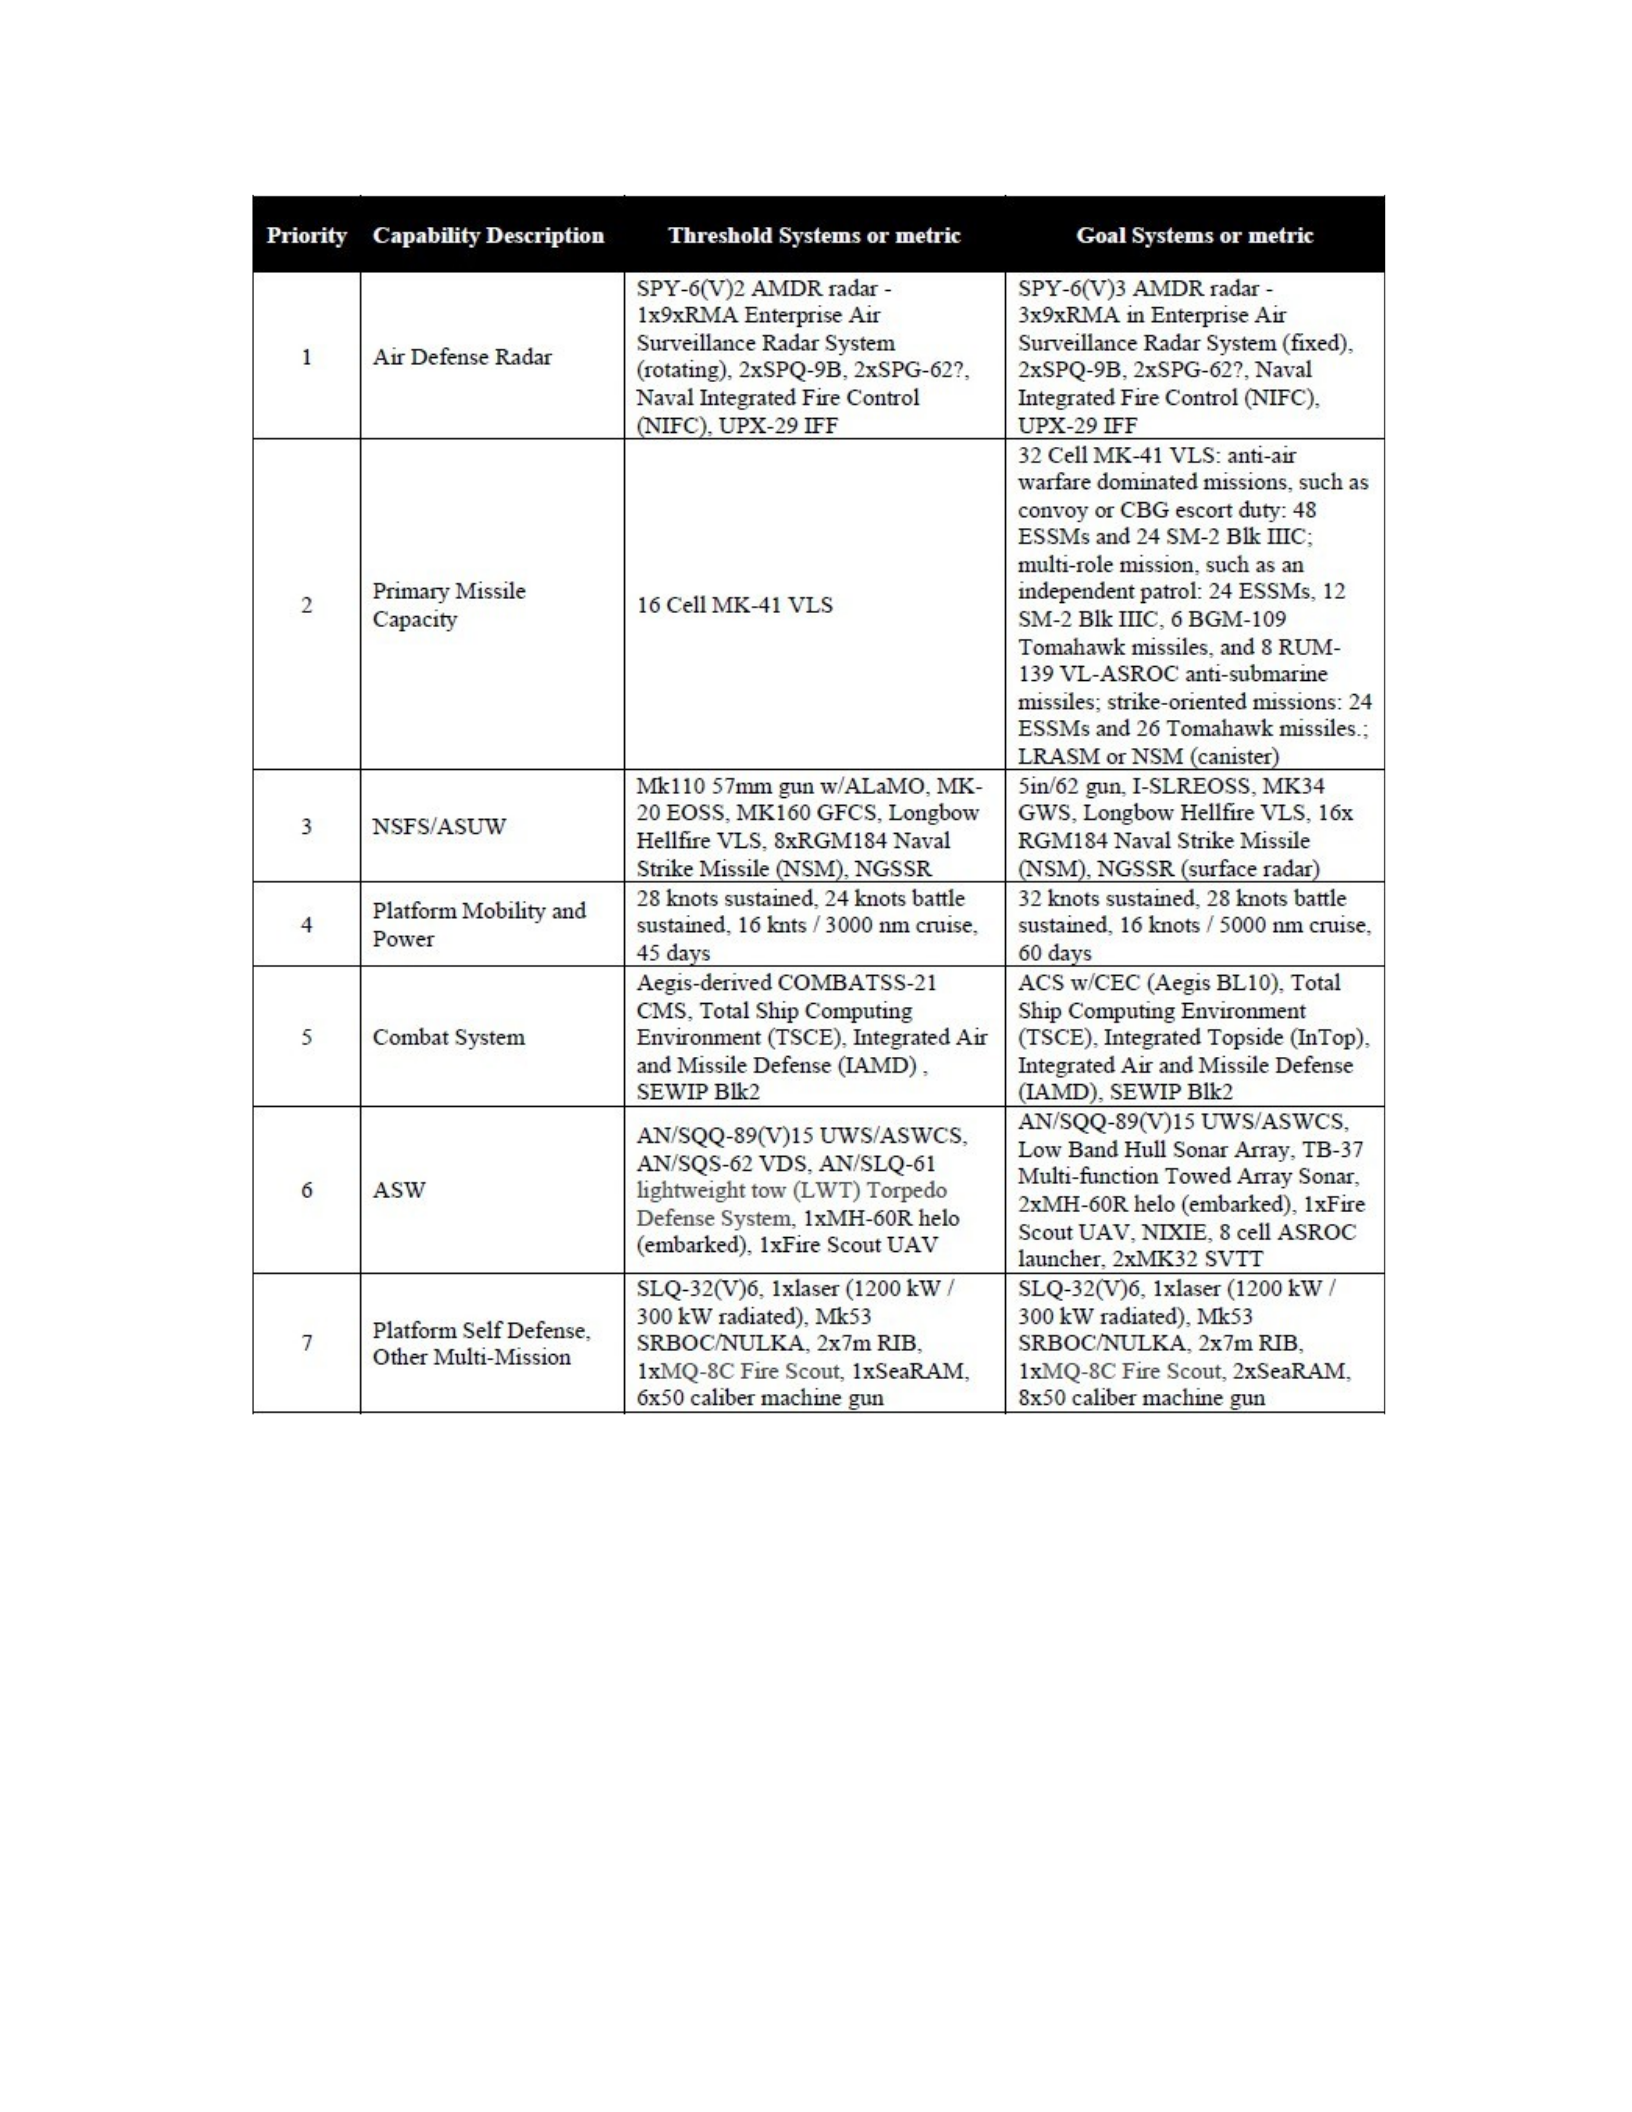
33
Table 4.2: Design Parameters of FFGVT Combat System
To ensure that the design can be capable of carrying out this mission, the
following Combat System Configuration is incorporated into the Synthesis Model
Design Parameters and Design Variables worksheets in the synthesis model.
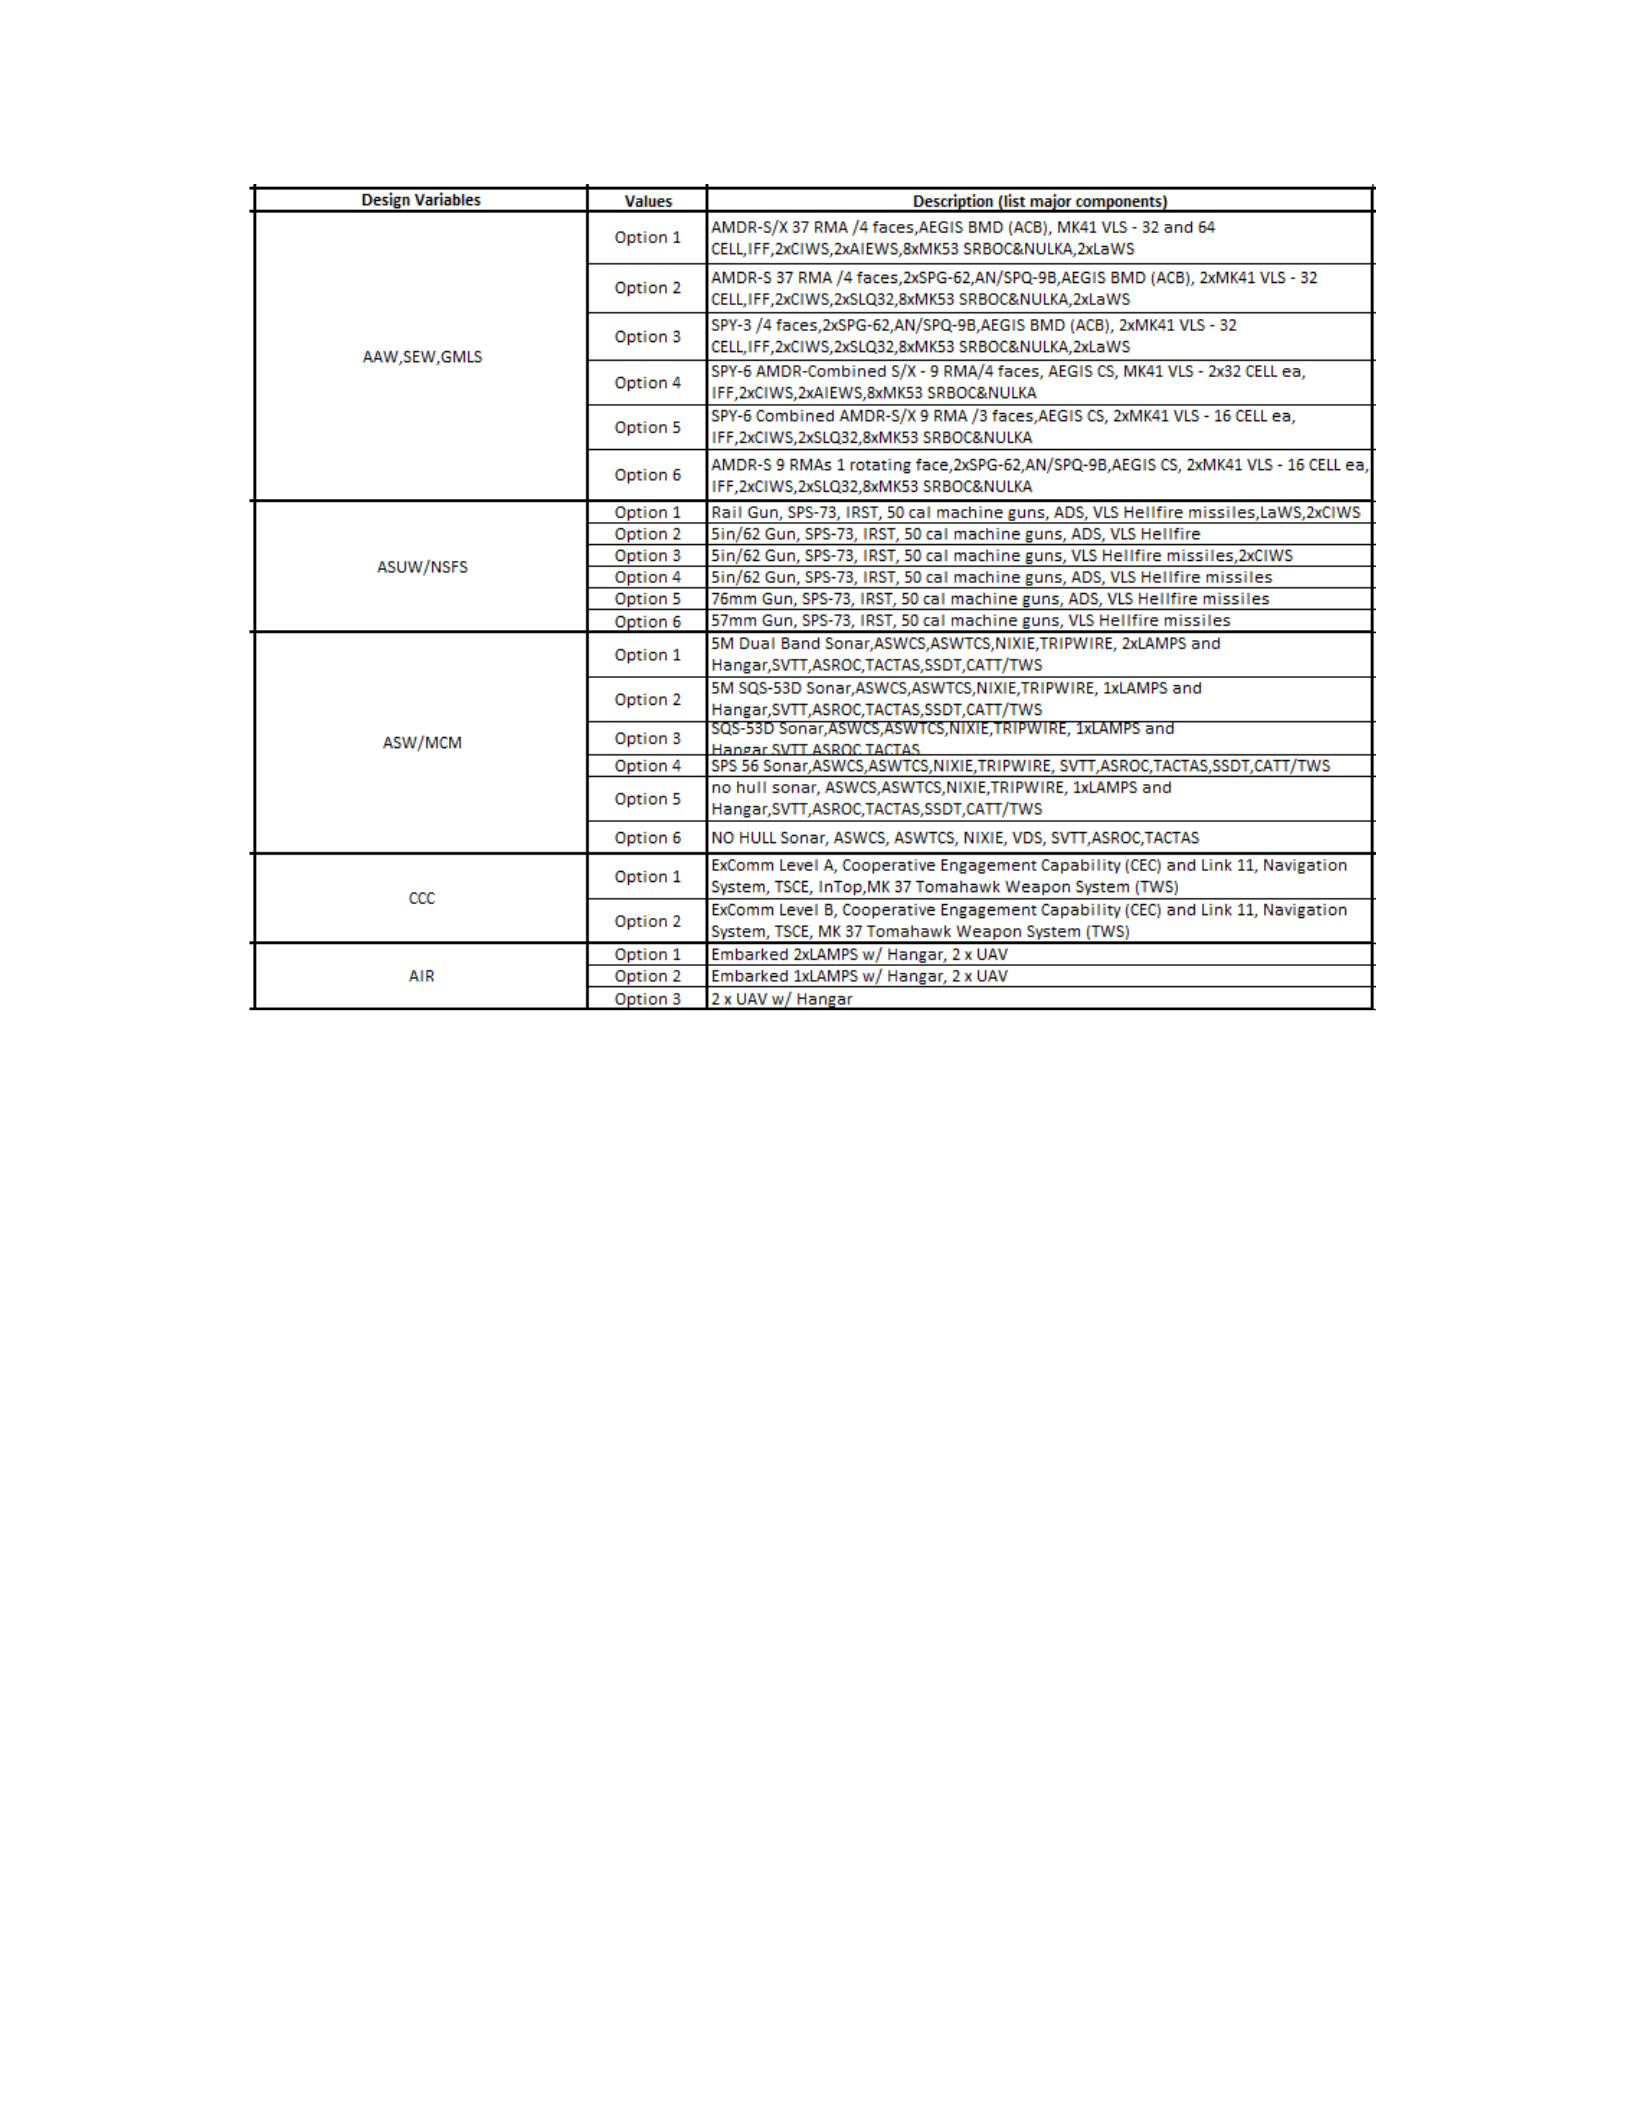
34
Table 4.3: Design parameters of the FFGVT combat system
Design Parameters and Design Variables were incorporated into the Model
Center Experimental Design tool to produce 200 representative hull shape variants to
visualize the design space and analyze the effect of hull shape DV on hydrostatics,
marine maintenance, and propulsion performance [5]. T h i s D O E d a t a i s t h e n
c o n v e r t e d i n t o R S M a s d e s c r i b e d i n C h a p t e r 2 . M u l t i -
O b j e c t i v e o p t i m i z a t i o n w a s c o m p l e t e d s e p a r a t e l y f r o m t h e
D O E , a n d c e r t a i n d e s i g n s w e r e s e l e c t e d b y t h e r e s e a r c h t e a m
t o p r o c e e d . T h e o p t i m i z a t i o n r e s u l t s i n c l u d e P S Y S = 7 ( H E D ) ,
A A W = 4 , A S U W = 6 , a n d A S W = 7 , w h i c h a r e p r o p u l s i o n p l a n t
a n d c o m b a t s y s t e m c o n f i g u r a t i o n s t h a t p r o v i d e t h e b e s t r a t i o
o f o v e r a l l s i z e e f f e c t i v e n e s s v s . c o s t . F u r t h e r e x p l a n a t i o n o f
t h e e x p l o r a t i o n o f t h e d e s i g n s p a c e a n d t h e r e s u l t s o f
o p t i m i z a t i o n w i l l n o t b e d i s c u s s e d i n t h i s p a p e r . N o w t h a t a l l
e n g i n e e r i n g a n d c o m b a t s y s t e m V C s t o b e i n c l u d e d i n t h e
35
d e s i g n a r e k n o w n , a n e w i n i t i a l s e t u p t o o l i n G r a s s h o p p e r c a n
b e u s e d t o v e r i f y t h a t t h e d e s i g n c o n t a i n s
area and volume are
sufficiently regulated to be considered decent.
4.1 Hull Subdivision Using Orca V2.5
Once the optimization is complete, the focus of the design work is shifted back to the
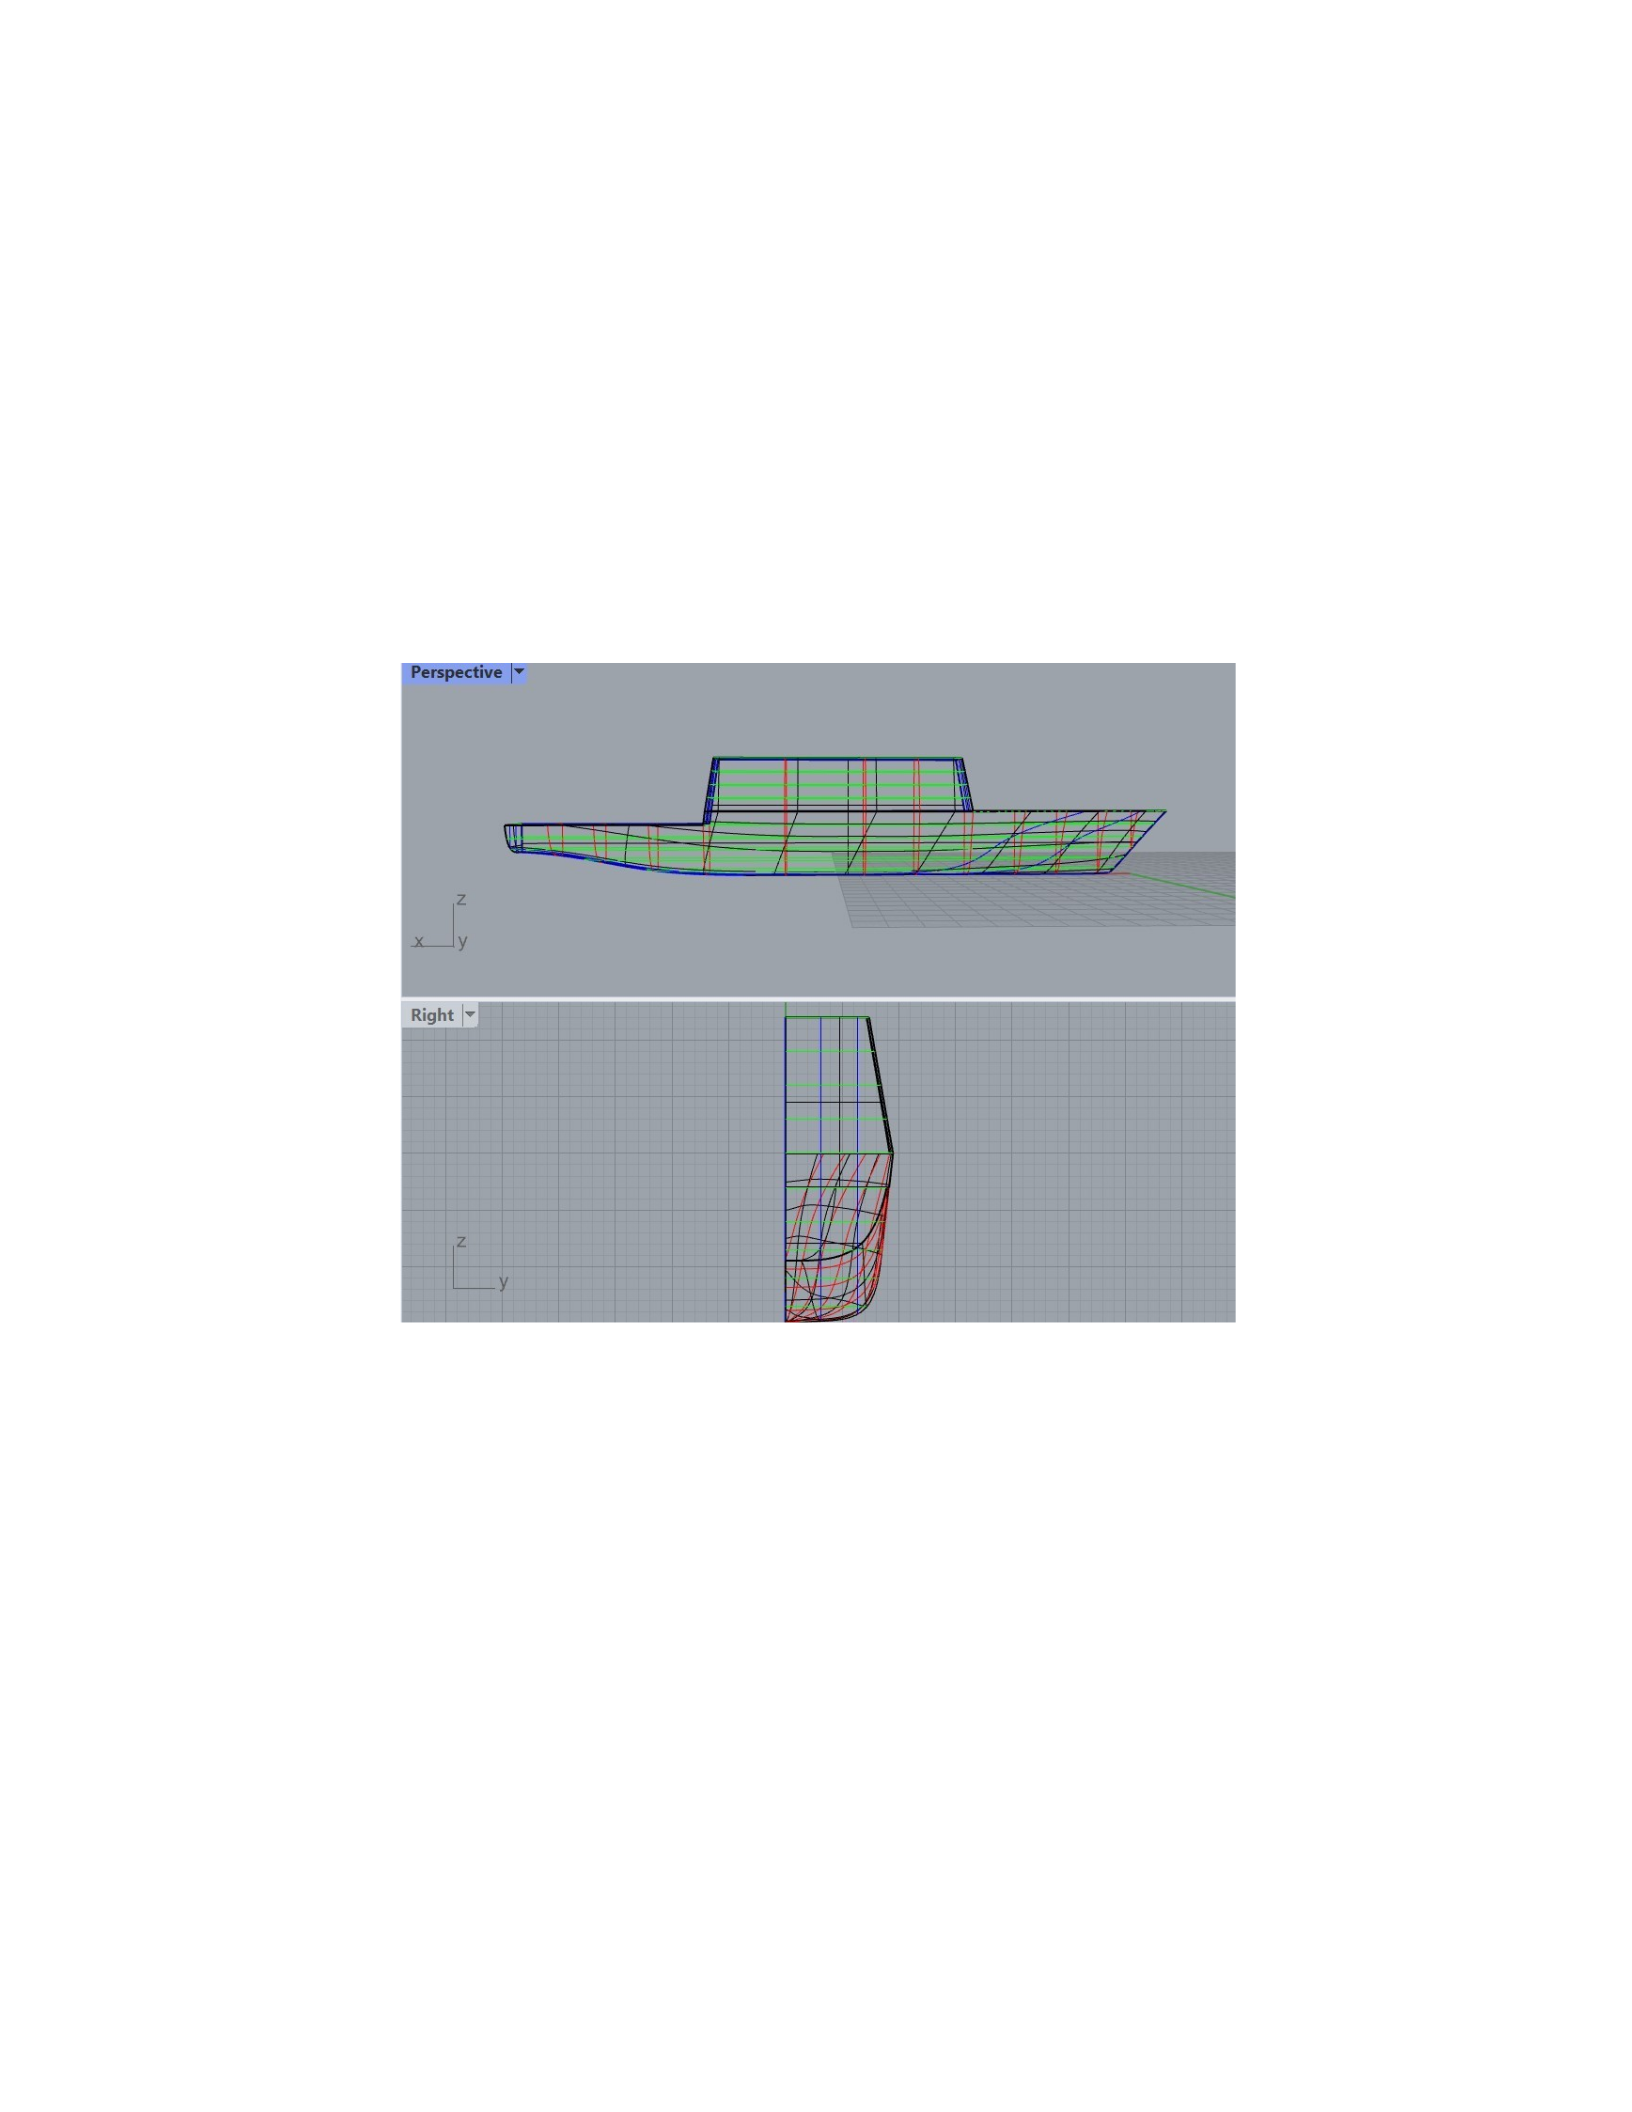
three-dimensional hull model in Rhino shown below.
Figure 4-1: FFGVT Rhino model (half-hulled)
The hull was then subdivided using the Orca V2.5 Work In Progress module in
Rhino 7. One of the important steps required to complete this process is that the
designer must ensure that the hull is a closed poly surface to carry out the
functionality of the Orca V2.5. This can be challenging, and most problems occur at
the intersection point between the deck house and the hull. The locations for
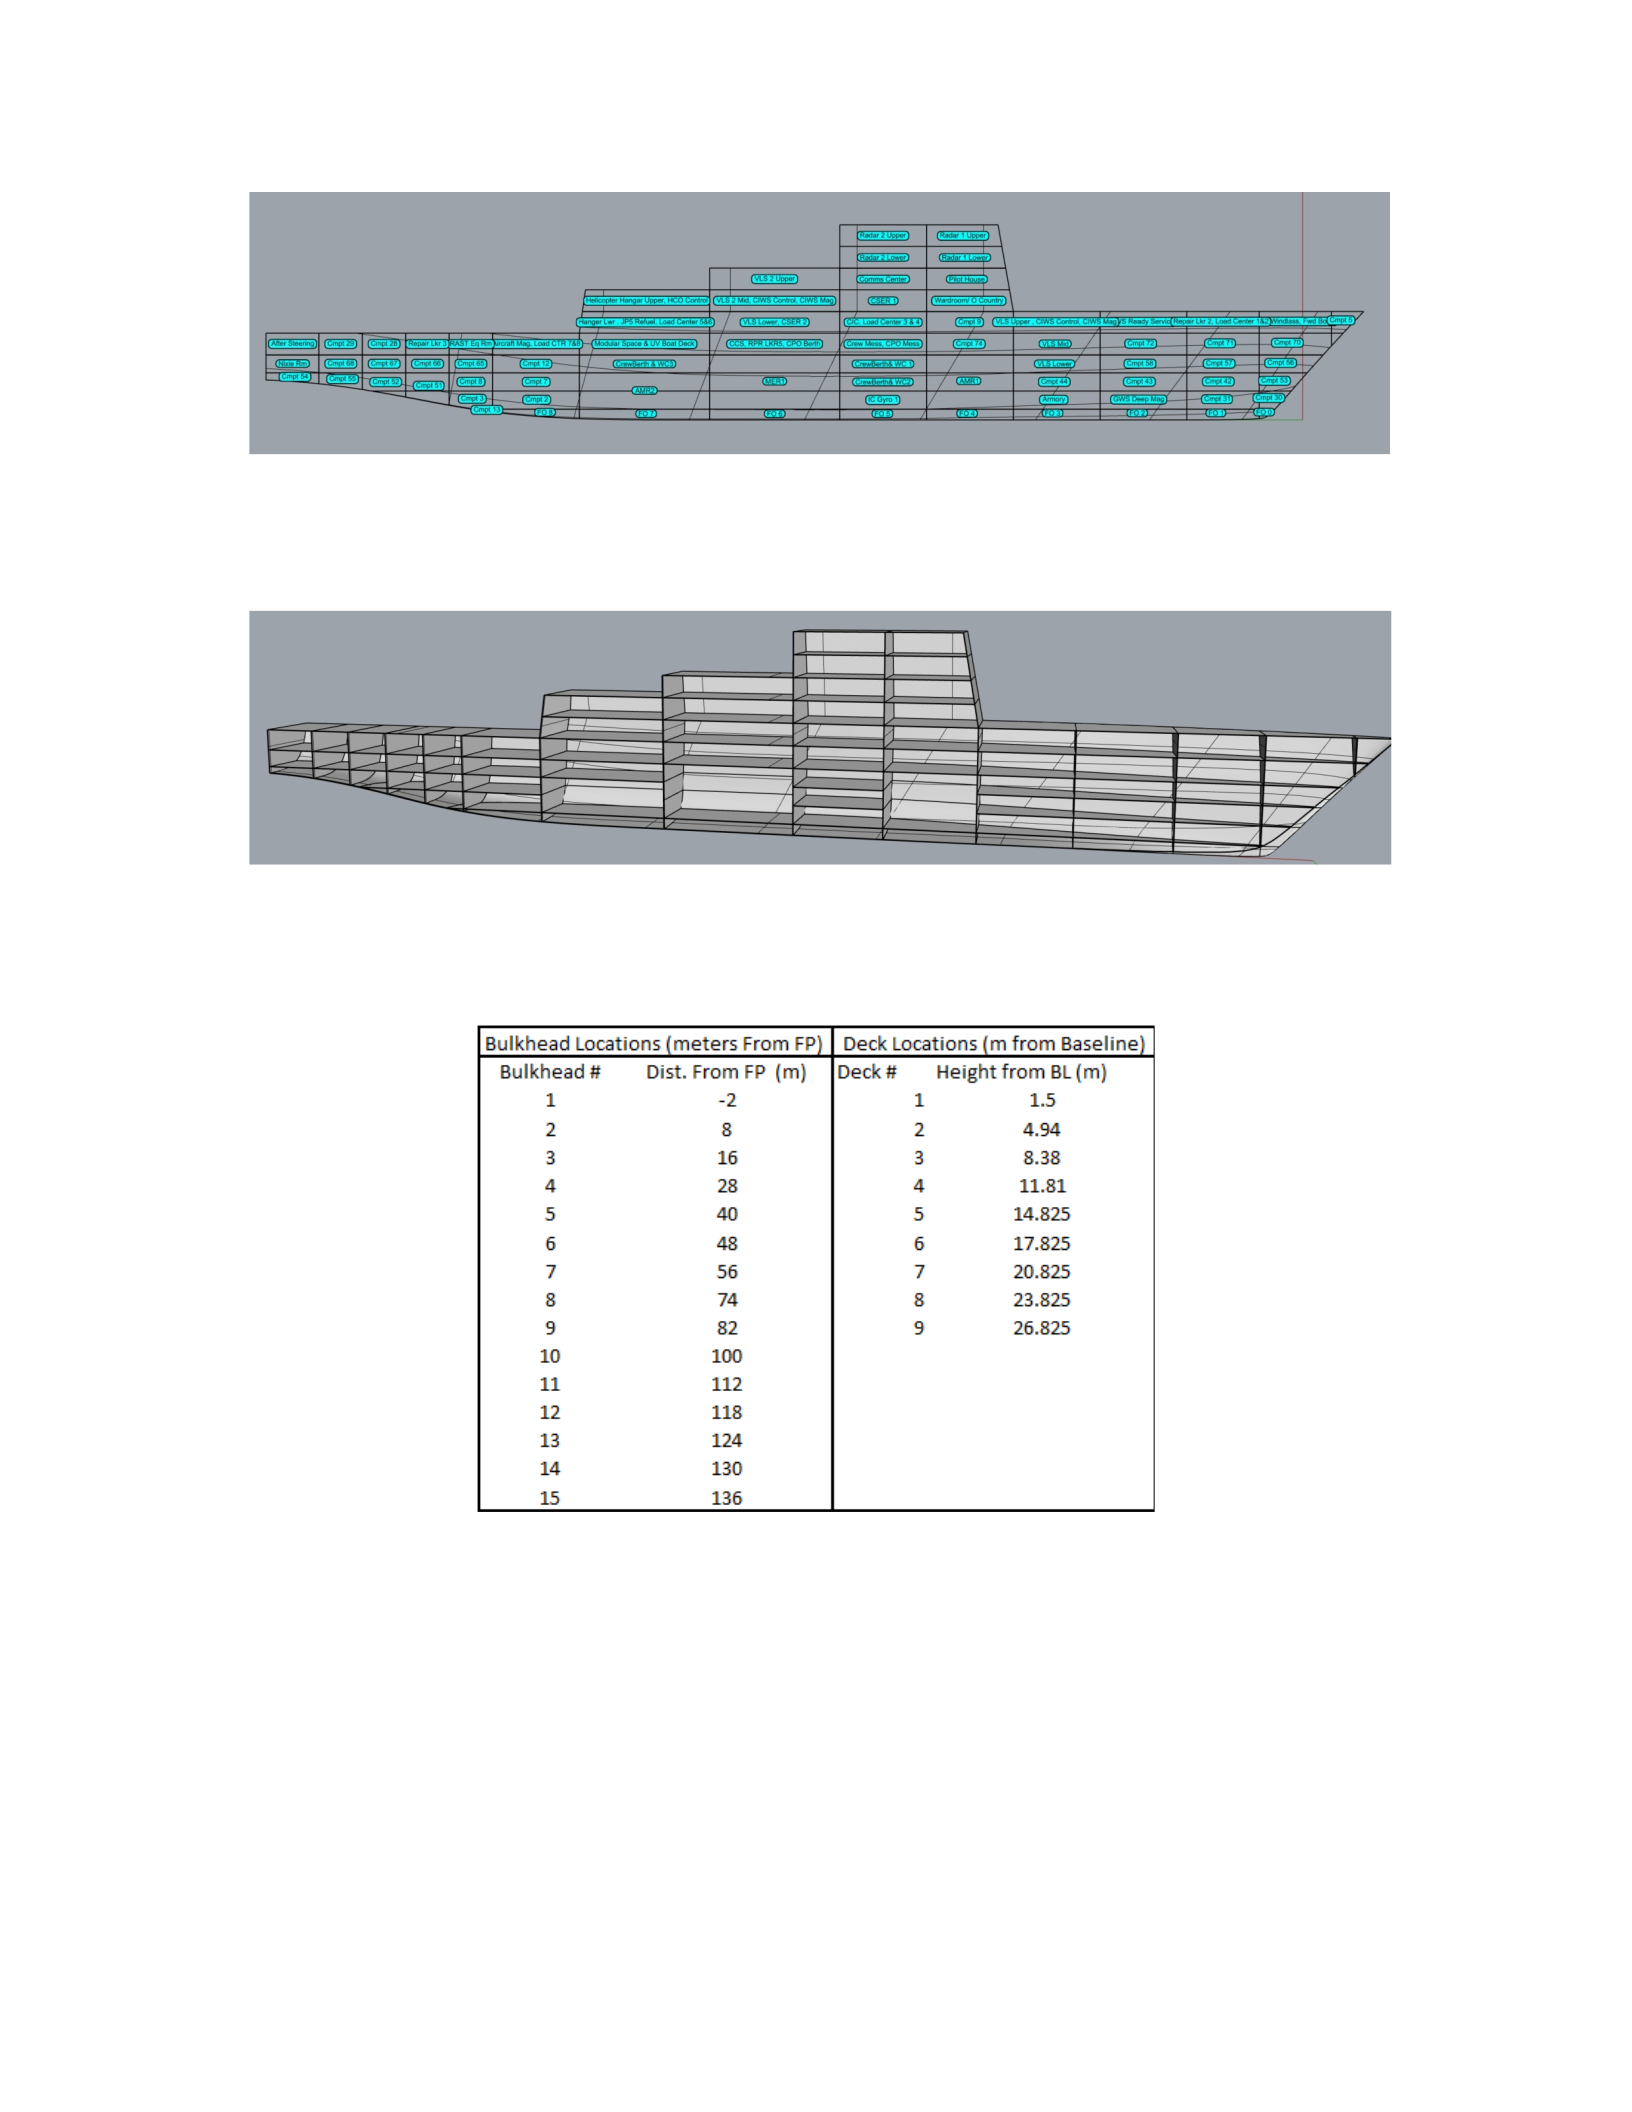
bulkheads and decks are automatically calculated by the subdivision module and
their
locations are displayed under the profile view and the model perspective showing
the
completed subdivisions.
36
Figure 4-2: FFGVT Subdivision
Figure 4-3: FFGVT Subdivision (Perspective View)
Table 4.4: Location of FFGVT Bulkheads and Decks
In order to create the correct geometry for large compartments such as helicopter
hangers and all engineering spaces, compartment surfaces such as decks need to be
removed in order to open the compartments to the correct size and allow the right
space for large components to be placed. The naming convention for components is
taken from the "settings" worksheet in SSM, which shows
37
Compartment block diagram and assigned compartment name. This worksheet is not
updated automatically during the design process therefore manual changes will be
required to adjust the diagram for larger or smaller surface vessels. For the purposes
of this project, only transverse bulkheads and horizontal decks are placed into the
model, although the placement of longitudinal bulkheads is possible using the Orca
V2.5.
4.2
Initial Setup of Vital Components
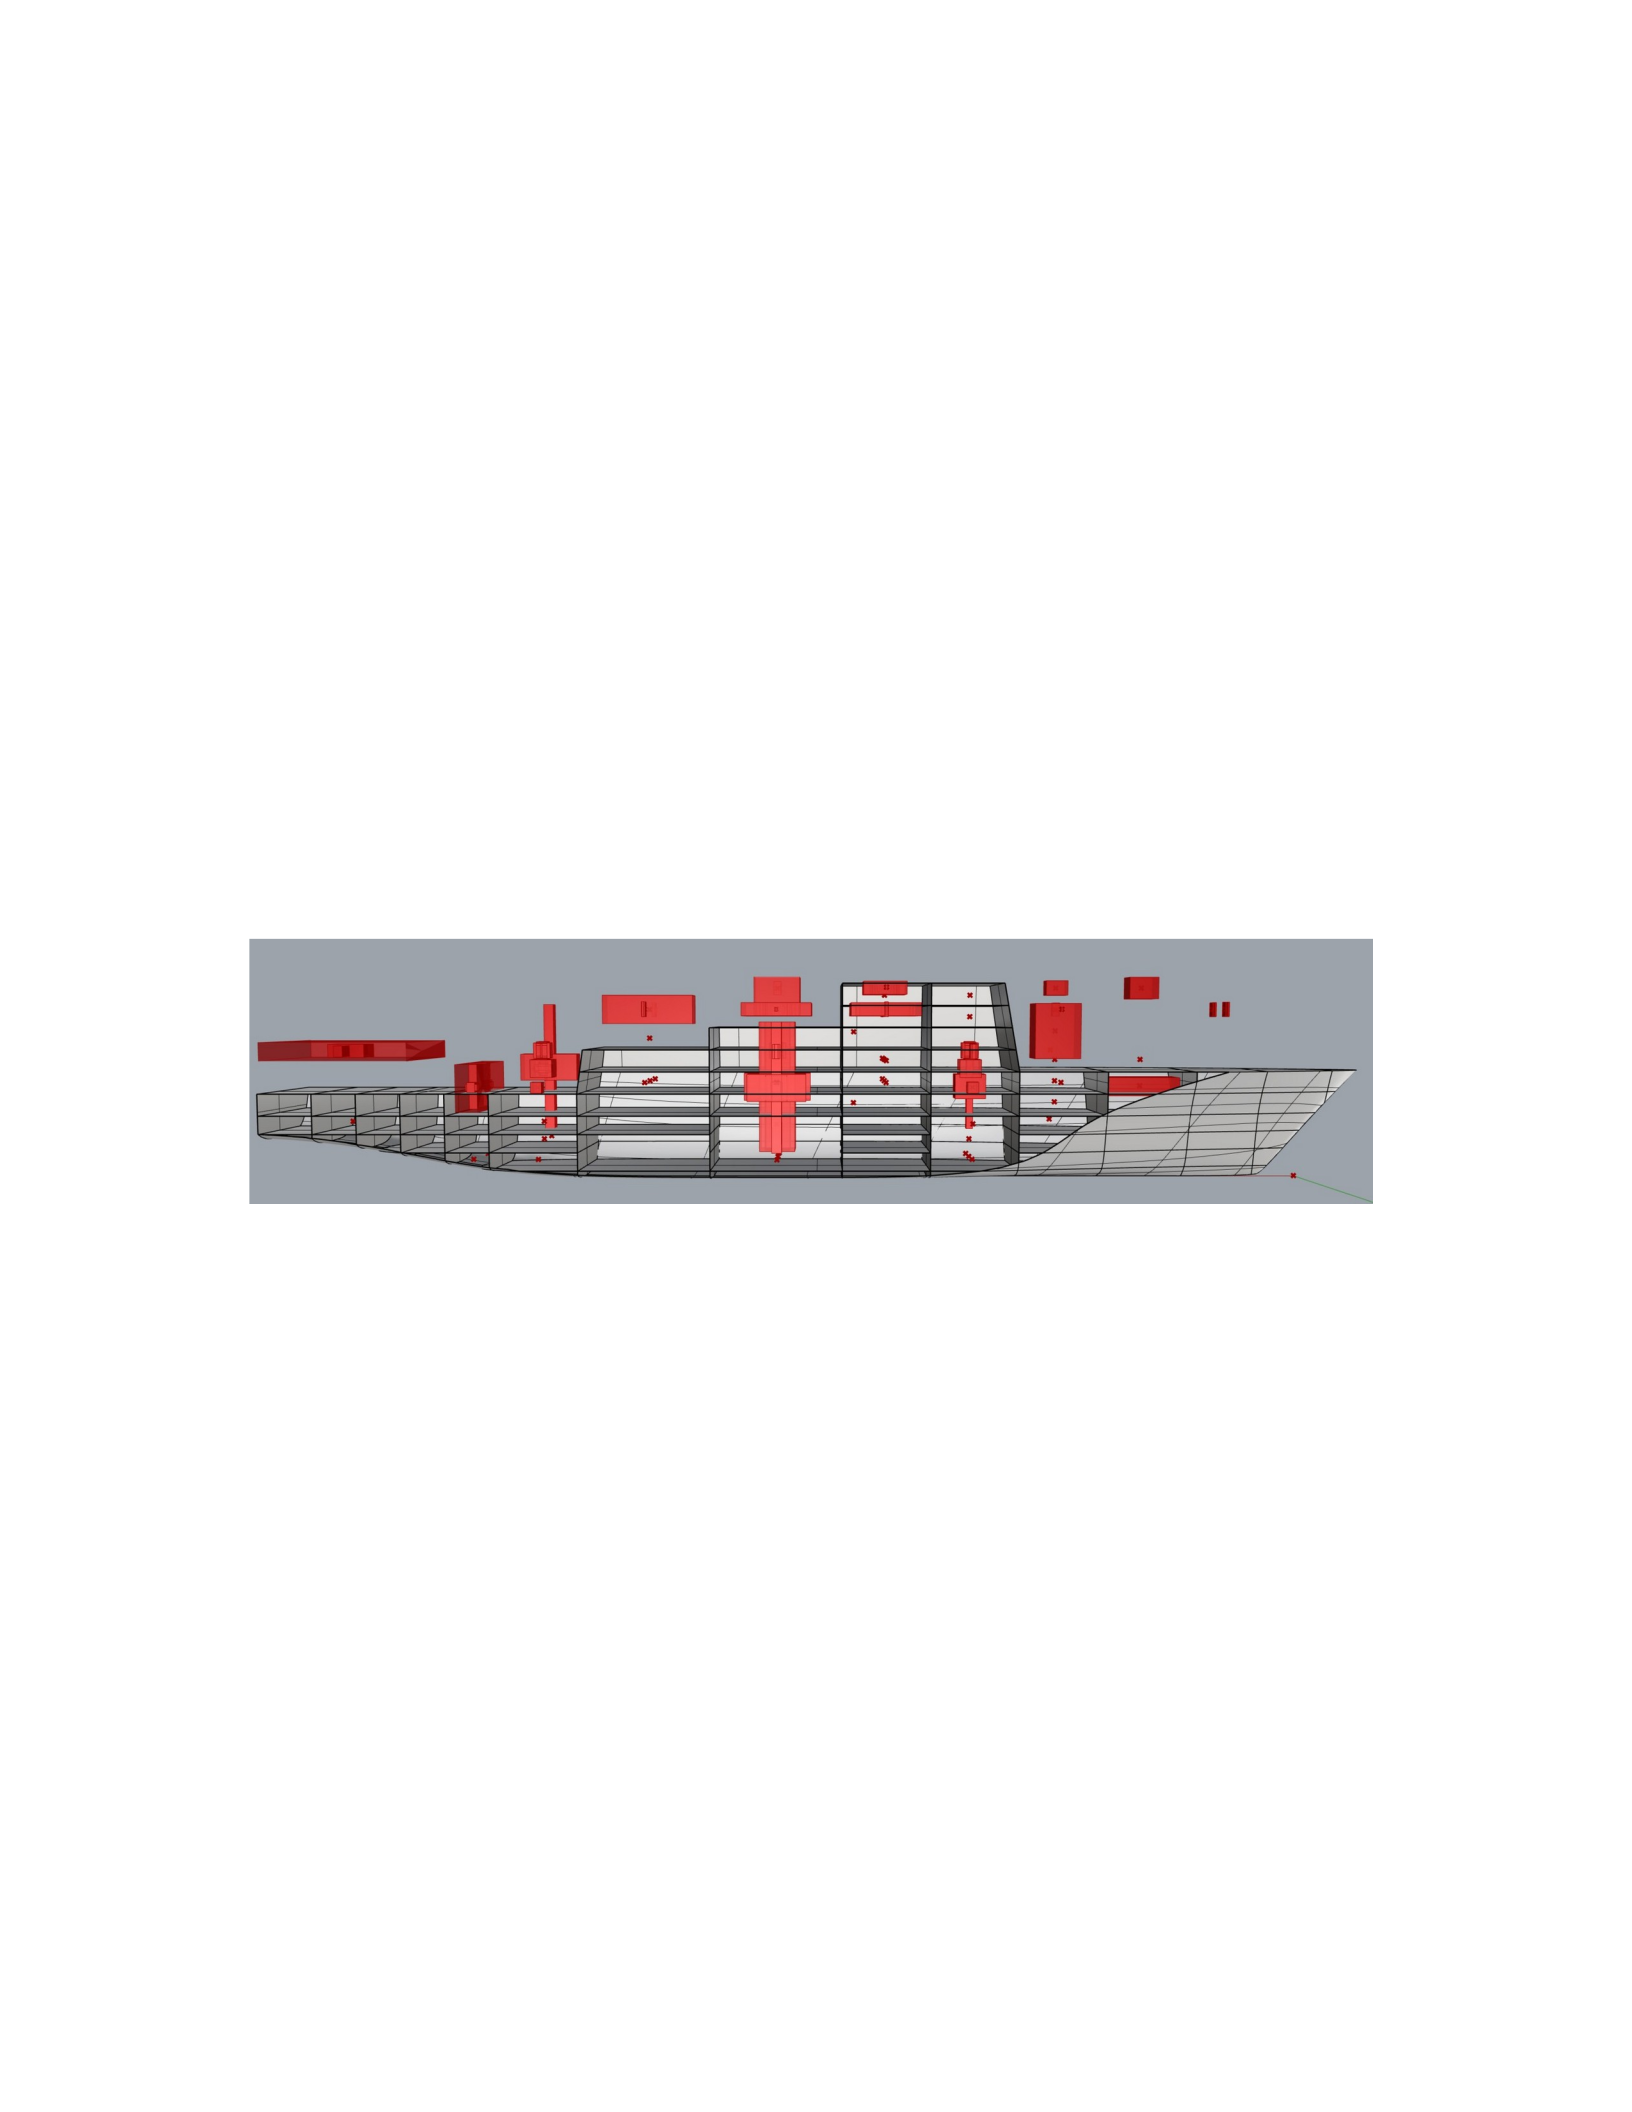
The initial setup tool is loaded into the Rhino workspace, and the correct data range
is imported from the SSM to the FFGVT hull as shown below. As mentioned earlier,
Rhino objects are red at this point and are just sketches where VCs will be placed
automatically until they are baked into the model by Grasshopper.
Figure 4-4: VC made by Grasshopper and Placed into the Stomach
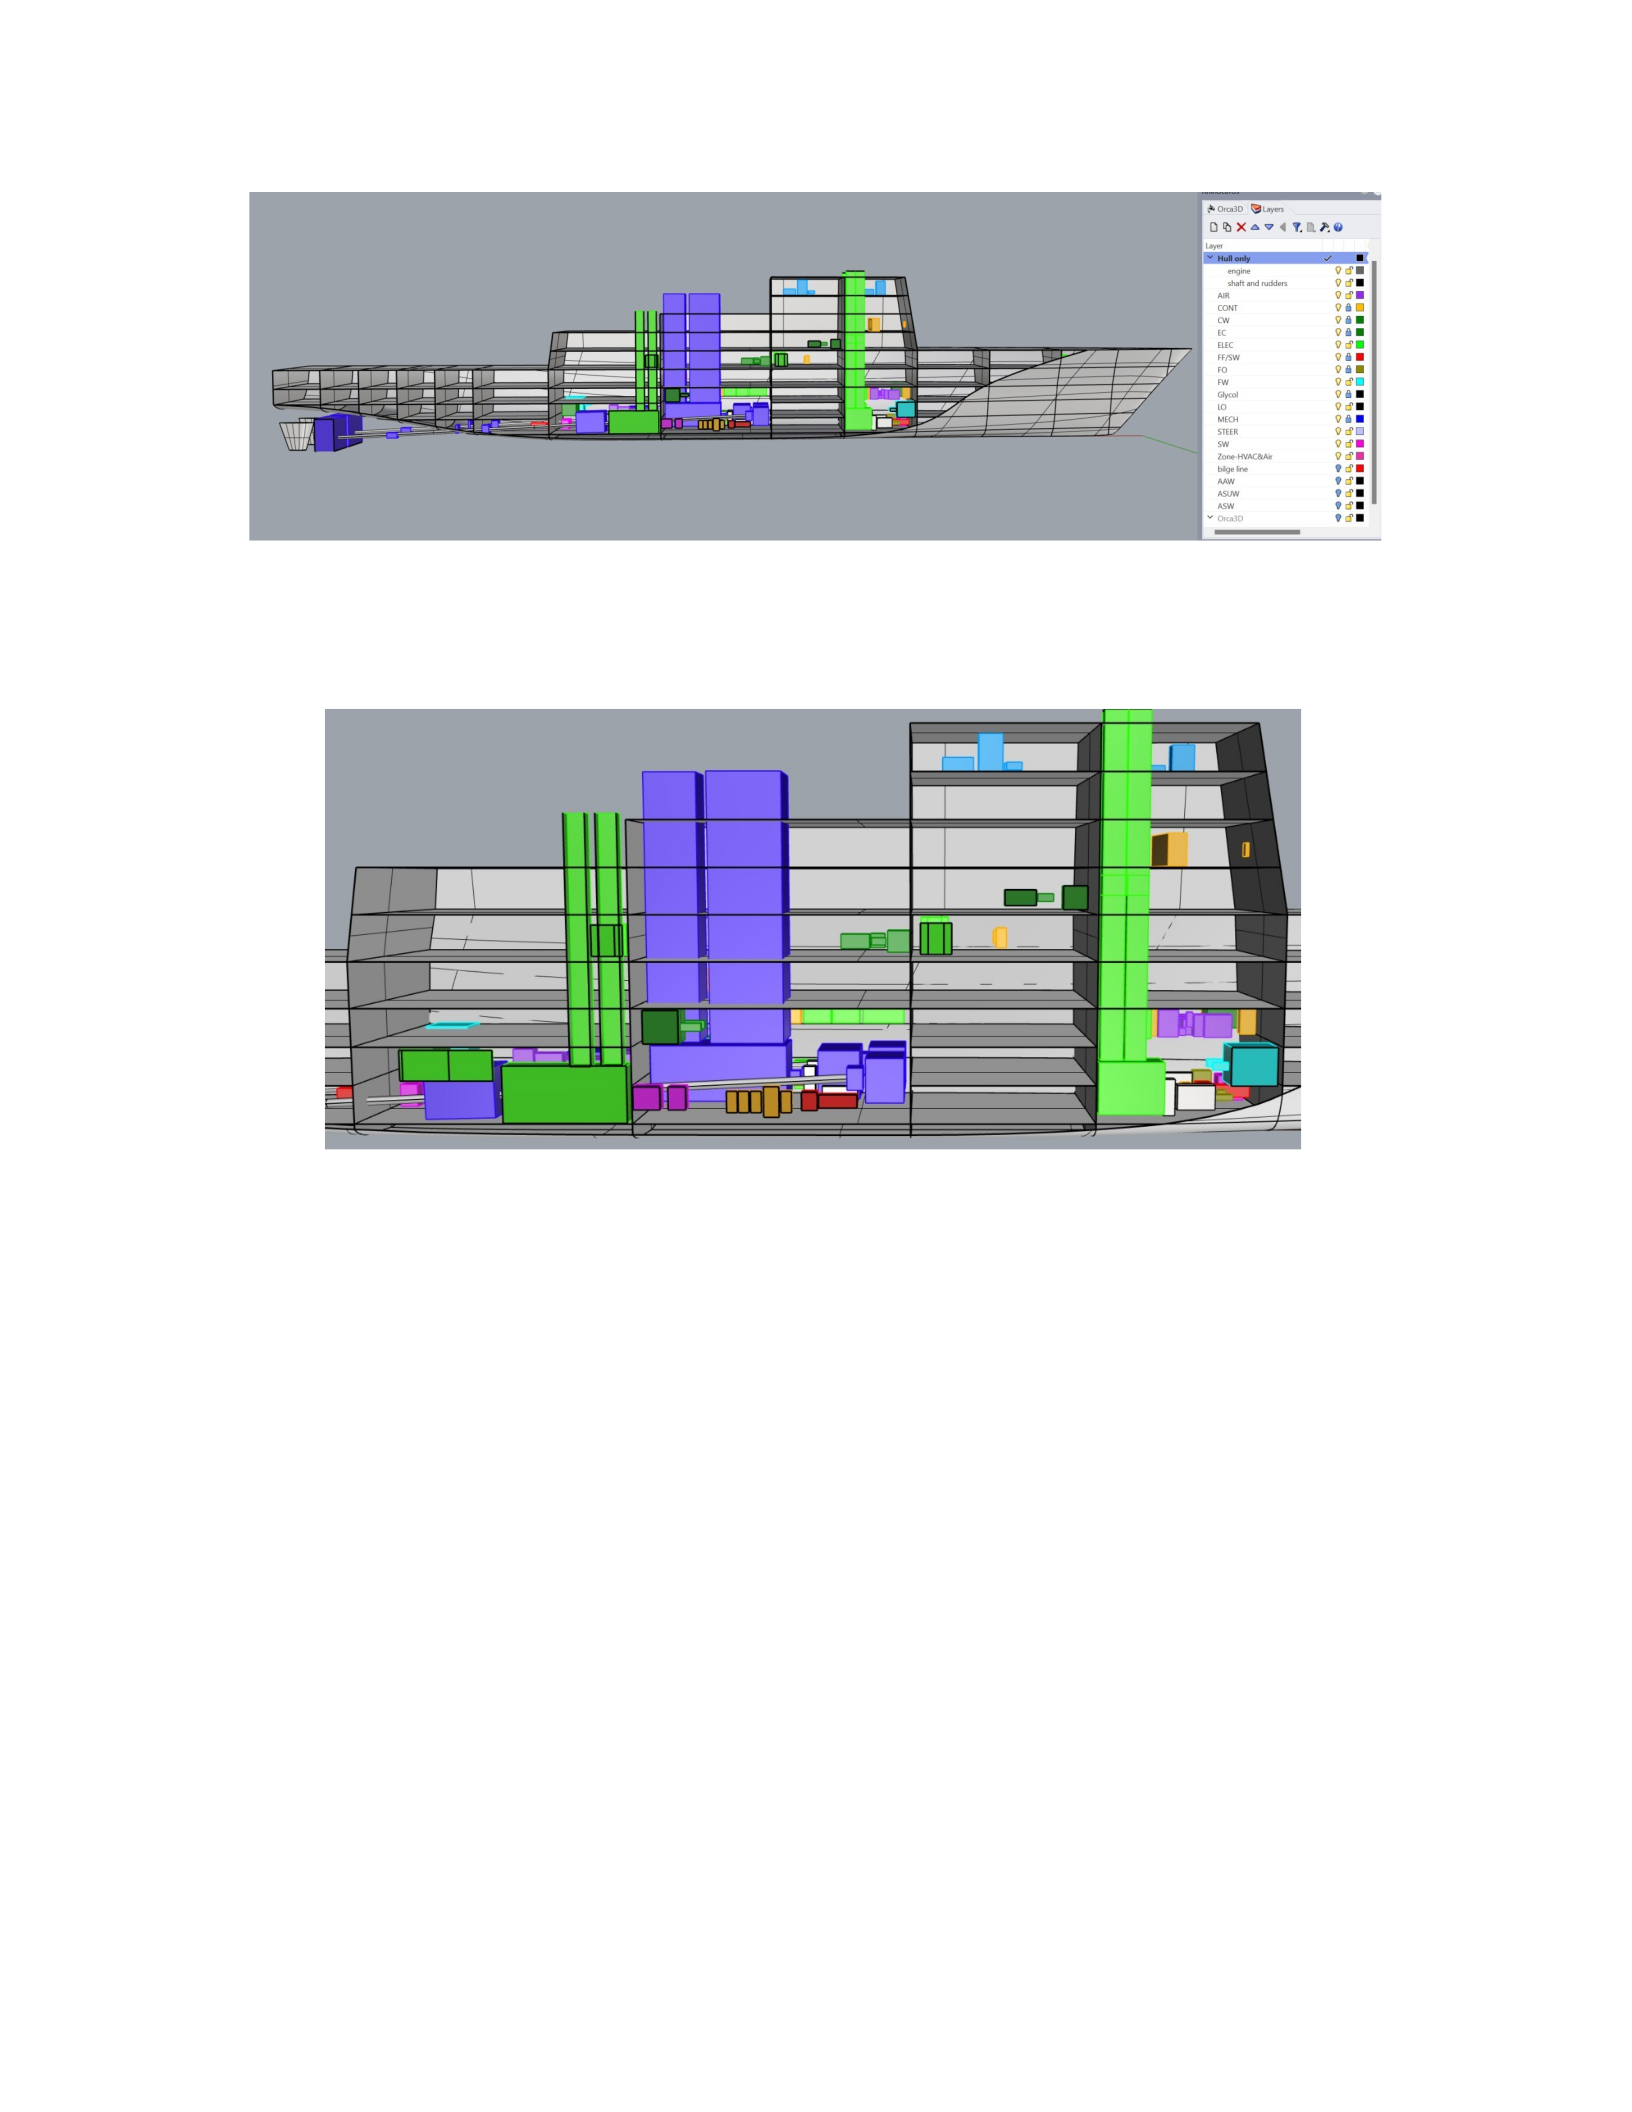
The initial setup for FFGVT begins with a VC listed outside the MECH plex of
PSYS=7 including one gas turbine main propulsion engine, cross reduction gears,
two second reduction gears, two electric propulsion motors, and associated bearings
and stern tube seals found along the shaft line. All other layers set by plex are turned
off to tidy up the port-view. Also included in this plex are the inlet and exhaust for
the main drive engine, which is one of the largest VCs. To account for the hull in all
engineering spaces, a temporary poly surface is added with a height of 0.5 meters
from the compartment body to ensure that all VCs are placed at least 0.5 meters from
the

38
deck to take into account the hull space. This temporary surface is then removed to
reduce clutter in the view-port. The most complicated challenge to set up the VC of a
propulsion system is to determine the angle of the shaft to Main Engine Room 1
(MMR1) or the farthest point that the shaft into the boat must reach from the
propeller. A very important design point is the need to determine the correct
propeller tip clearance between the top of the propeller blade and the bottom of the
hull, as this will help determine where the shaft line will fall into the engine
compartment. The clearance of this tip can be measured from the center of the top
surface of the Rhinoceros object representing the propeller to the bottom of the hull.
In this case, the shaft is of the same length and both end up on the thrust bearing
located in MMR1. It is driven by the GTM forward cross reduction gear which is
placed on the center line because the two outputs of these cross reduction gears must
be at the same shaft angle. For ship classes with different shaft lengths such as DDG-
51 or CG-47, different shaft angles will be present and cross reduction gears cannot
be done unless the main drive can be set between the waterproof bulkheads. The
angle of the FFGVT shaft is 3 degrees and is measured using the "angle" command
in Rhino by drawing a line through the center of the shaft, and another along the XY
axis. The angle between these lines is the angle of the shaft. Due to the deadlock of
the shaft against the thrust bearing, this is generally the next component that can be
adjusted, followed by the reduction gear, and the main drive. Since the angle and
location of the shaft are known, the line shaft bearings, stern tube seals, and support
bearings can now also be adjusted. Supporting calculations for the location of the line
shaft bearing can be used to further improve the accuracy of this setting. The line
shaft bearing is placed evenly along the shaft in this example and rotated to the
correct shaft angle three degrees.
39
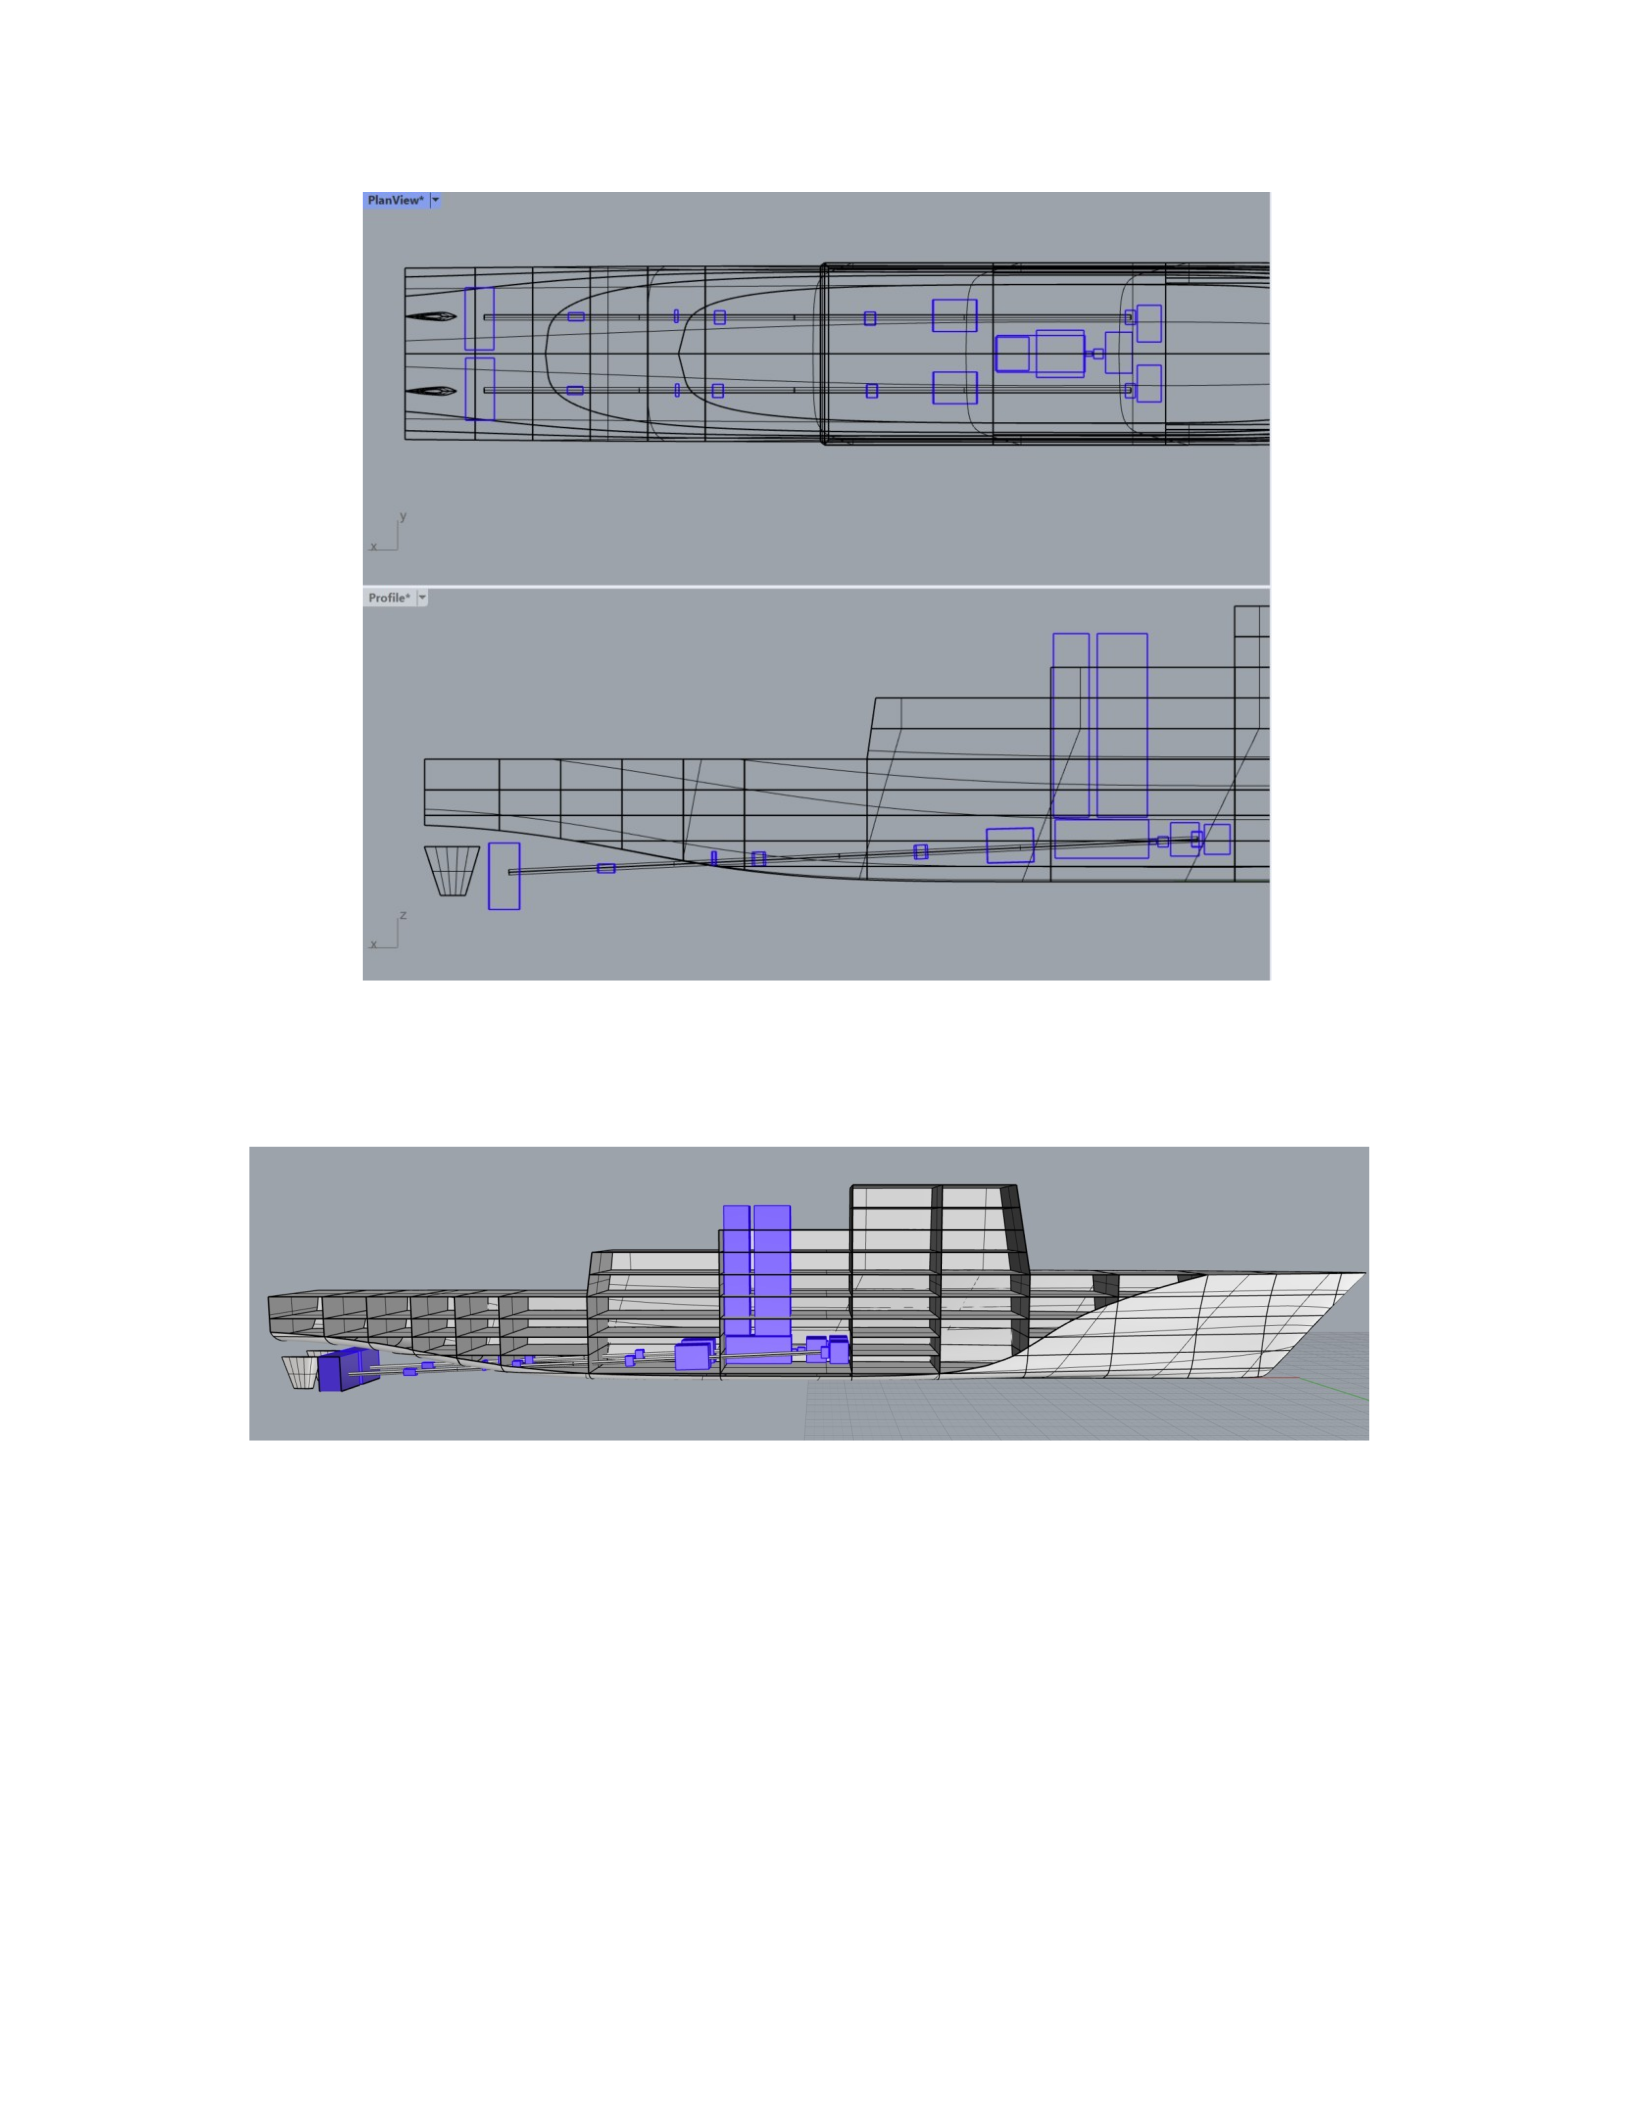
Figure 4-5: Plan View and MECH plex Setup Profile View
Figure 4-6: Perspective View of MECH plex Settings
As seen in the image above, there are several view-ports that help in executing
the general settings. Through practice, it has been determined that the most effective
method of conducting regulation is to utilize the "Plan View" (waterline view in
naval architecture) viewing port to control transverse movement in the XY plane, and
"Profile View" to control vertical movement in the X-Z plane. Both the "Ortho" and
"Osnap" commands are very helpful to the designer in controlling

40
VC movement and improve design symmetry because VC movement is limited only
in the orthogonal direction. Once the appropriate transverse and vertical movements
have been made, it is useful to check these changes in the view-port "Perspective"
using the new Orca V2.5 clipping box feature, which can cut out parts of the hull to
reveal interior compartments. The perspective view should only be used for
situational awareness, as it is very difficult to move the Rhinoceros object in three
dimensions and will almost certainly cause unwanted movement of the object. These
view-ports are advantageous in identifying interference between VCs quickly
because the other three view-ports are two-dimensional and therefore become very
crowded with objects that seem to interfere with each other, but in reality can be
separated by vertical or transverse distances that cannot be seen in two dimensions.
Selecting the problematic VC in the perspective view ensures that the right VC is
selected and ready to be moved, and the designer can now move back to the profile
view or plan to make the necessary changes to address the disruption. The "Body
Plan" view of the Y-Z plan is also useful in some situations, but generally becomes
too dense with lines from other VCs and the hull.
The initial setup process then continues for other VCs whose previous layers were
turned off. The process used is to work with the layer that holds the most VC first,
and then progress to the layer with the fewest number of VCs, ensuring that the
finished layer is locked before the new VC layer to be set is brought to the front. The
temporary poly surfaces that represent the grate decking inside the engine
compartment are used to place the smaller VCs in the middle and upper levels of the
engineering space just as they would be on top of a real fighter. These grids are then
removed and not displayed to remove image clutter and to minimize the number of
active layers, but can be left inside the model or hidden if desired.
41
Figure 4-7: Complete Setup of all Engineering Critical Components
Figure 4-8: VC arranged in the Main Engineering Room
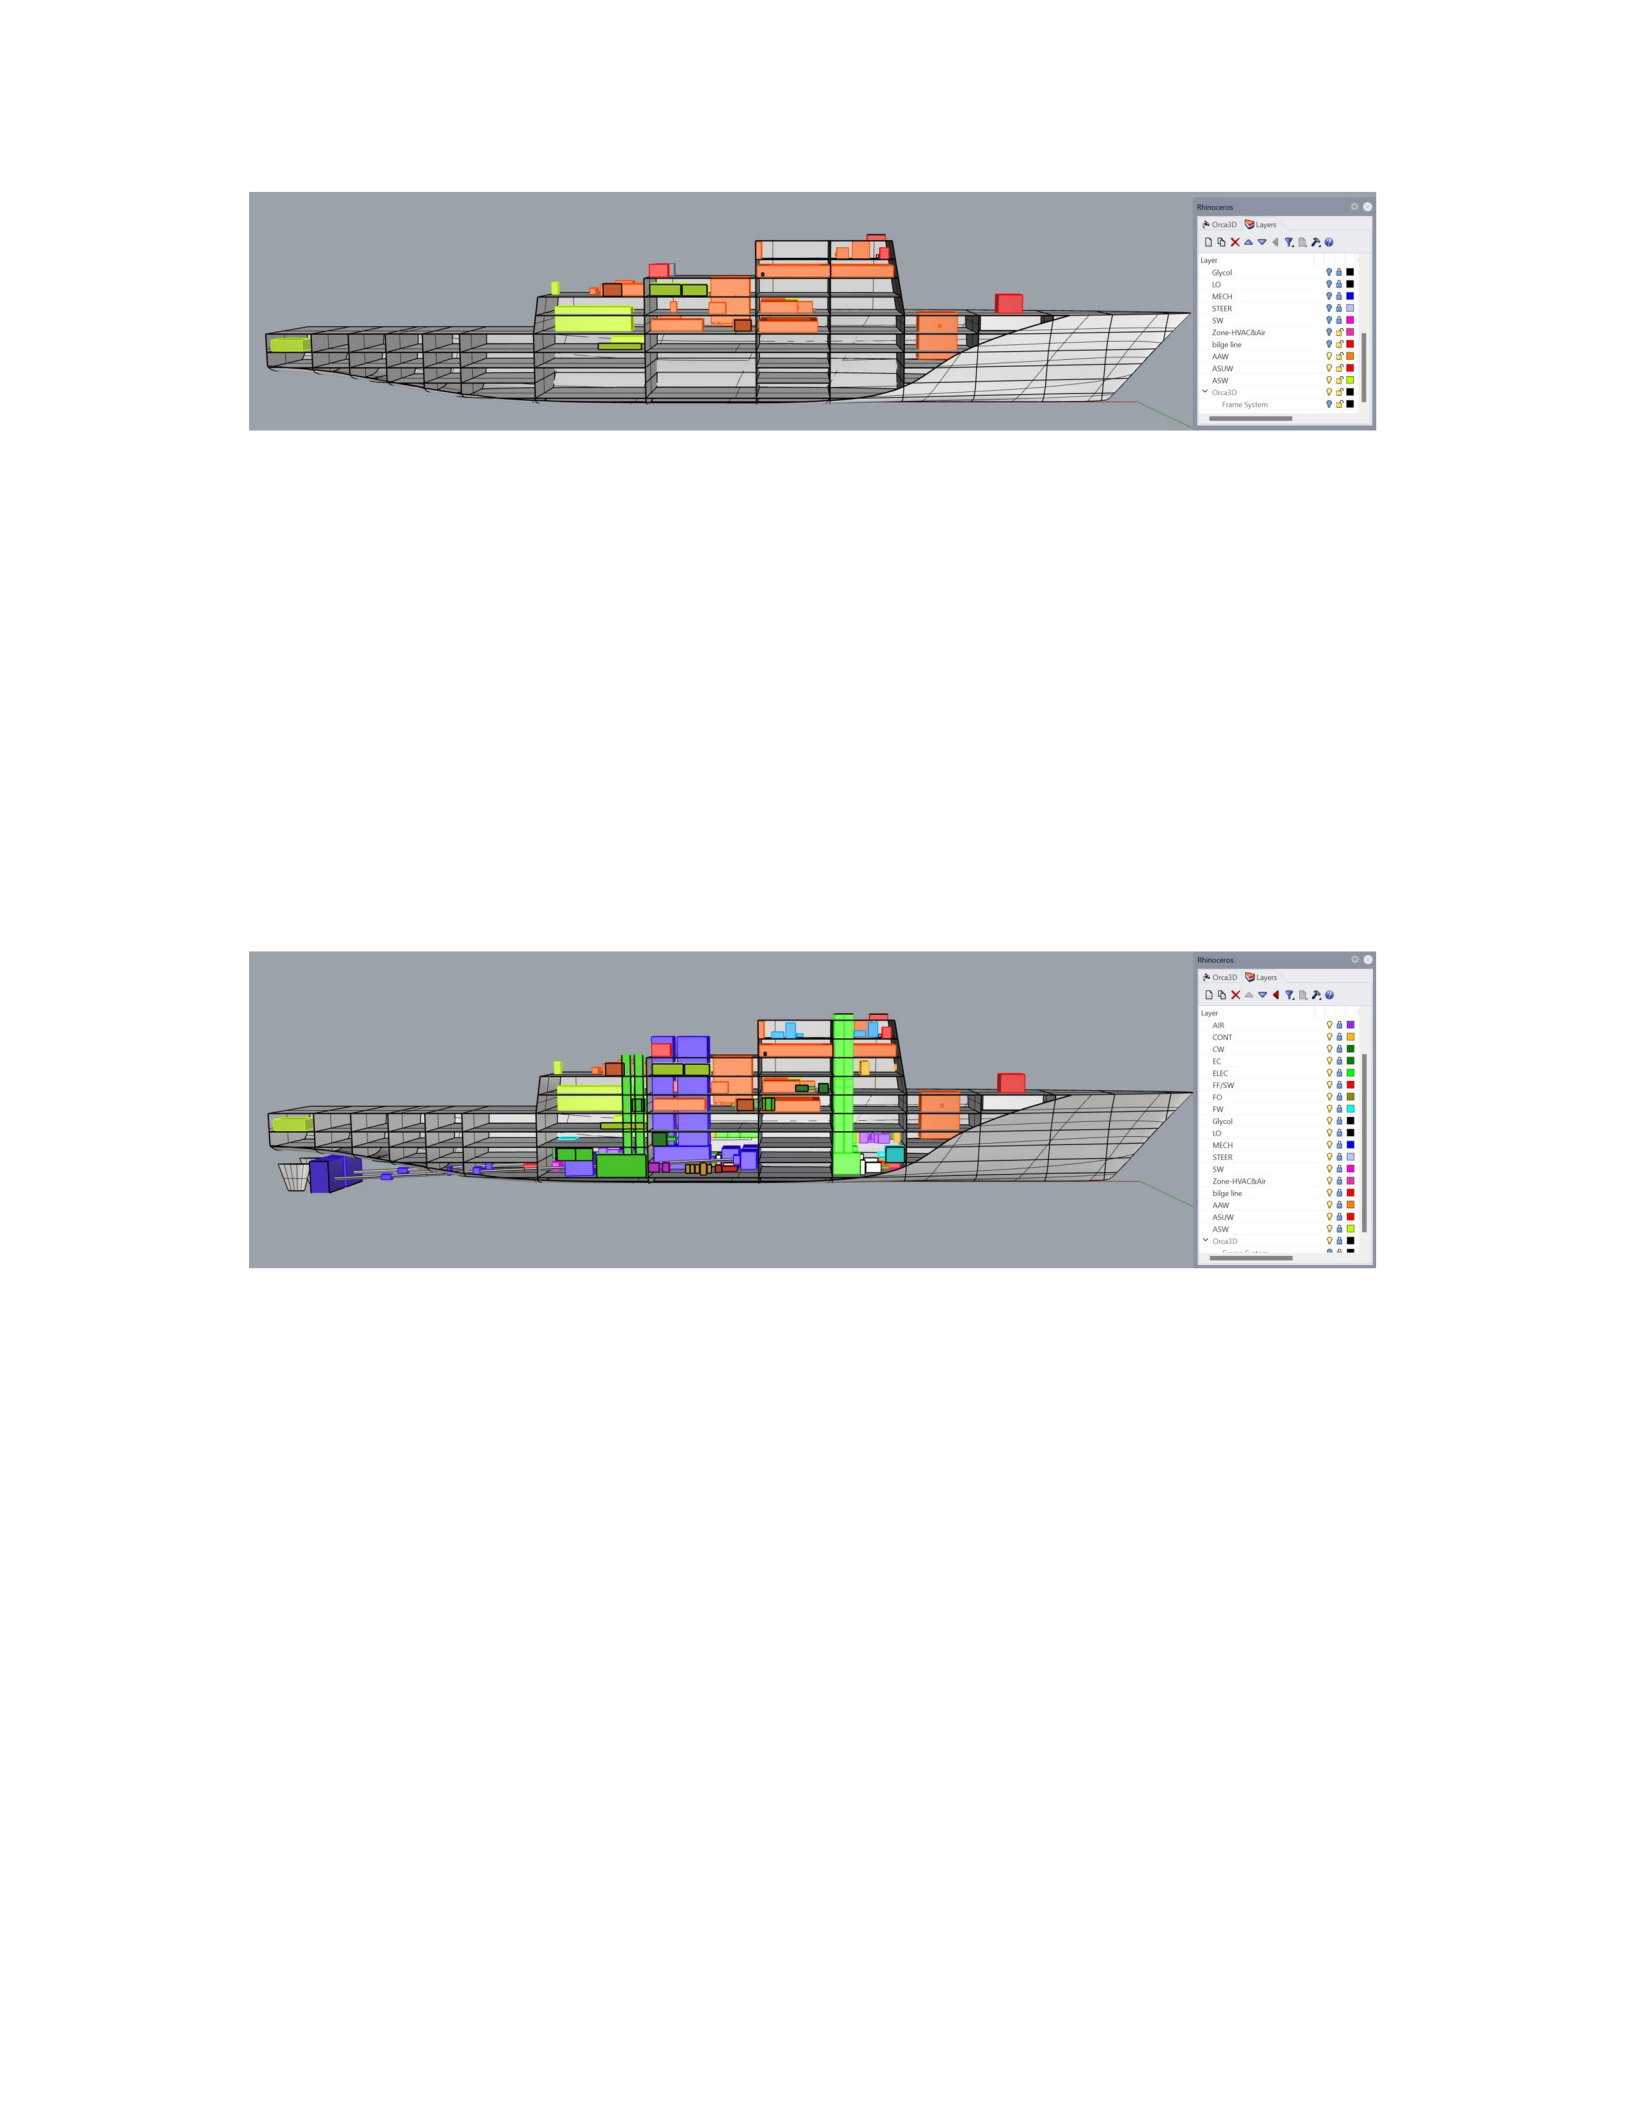
Figure 4-7 above shows the initial setup that has been completed for all engineering VCs.
The Rhino layer menu is displayed on the right side of the image and shows the layers of the
hidden AAW, ASW, and ASUW combat systems. These layers are now brought forward one
by one and the process continues to complete the initial setup of the FFGVT. The AAW plex
contains most combat systems, VCs and large objects such as a 32-cell VLS. VC ASW and
ASUW contain fewer objects. The full setup for the VC combat system is shown below. All
engineering VC layers are hidden in this view.
42
Figure 4-9: Initial Setup of VC Combat System
The initial setup for all VC engineering and Combat systems has now been
completed and the focus is now shifted to verify that there is no interference between
any VCs. It was found that most of the problems occurred around the inlet/exhaust
for GTM and diesel generators, and it was advantageous to leave the MECH and
ELEC layers on during the initial setup process to ensure that the VC was not placed
on the shaft line or into the inlet/exhaust stack.
Figure 4-10: FFGVT's Preliminary Indictment
Figure 4-10 above shows the FFGVT hull with all VC layers turned on, and
locked. At this stage the initial setup is completed and the design can move forward
in the C&RE process.

43
Chapter 5
Conclusion
Incorporating the proven design process of C&RE tools into the 2N program
provides a meaningful first step away from ASSET as a primary design tool and
eliminates the problems students face with the Distro A information found in
ASSET. This tool allows designers to dive deeply into important areas of design
while ensuring that other parts of the design process do not suffer. The C&RE tool
was built by the latest naval officers and architects with modern warship designs. The
tool will positively influence 2,705 future design projects, and these same projects
create a positive feedback loop into the synthesis model.
5.1
Further Research and Recommendations
The project has paved the way for future collaborative research between 2N and
Virginia Tech's naval architecture program that could continue to improve many of
the capabilities of C&RE tools. Incorporating Grasshopper into this project was
groundbreaking, and the creation of the initial setup tool showed what was possible
to create a better three-dimensional model of the ship in Rhino. Many engineers are
working to create plug-ins and more powerful upgrades to the Grasshopper, which
can be incorporated into the tool as well to create piping, conduits, or electrical
connections between Vital Components. When the VC reshuffle

44
The proximity matrix in SSM is complete, connectivity between VCs may be
possible in Grasshopper. This path should be explored, as it will greatly improve the
accuracy of the initial setup tool, and build the experience of learning to complete the
challenging setup of the Vital Components.
The C&RE research team has discussed the possibility of creating a new VC that
can represent components on the top side of the ship, such as small boats, capstans,
and equipment used for recharging at sea. This is recommended, as incorporating the
topside design into the Rhino model will further build on the battleship design
learning experience.
The ongoing collaboration between MIT and Virginia Tech at the graduate level
raises the likelihood that the C&RE tool will continue to improve and could become
the primary warship design tool used in academic settings.

45
Appendix
A
Guide to Using the Initial Setup Tool
This attachment will explain in detail the coding of Grasshopper behind the initial
setup tool and how to use the tool effectively to read Excel, create VCs, and organize
them into Rhinoceros Layers. Each part of the coding will be explained to help with
any potential troubleshooting required. Users should always ensure that the latest
Rhino update is installed as this will also automatically update the Grasshopper
accordingly. The McNeel Forum has been very helpful in resolving conflicts in
Rhinos and Locusts. A quick response to the issue can be expected on this forum and
is highly recommended for tool development as well.
Grasshopper is already installed into Rhino versions 6 and 7. To access
Grasshopper, Grasshopper needs to be added to the Rhino command list and
Grasshopper can also be opened by typing it into the Rhino command line. Many
references such as Parametricbydesign.com and food4Rhino.com have excellent
reference documents including video tutorials on how to successfully upload
Grasshopper and related plug-ins.
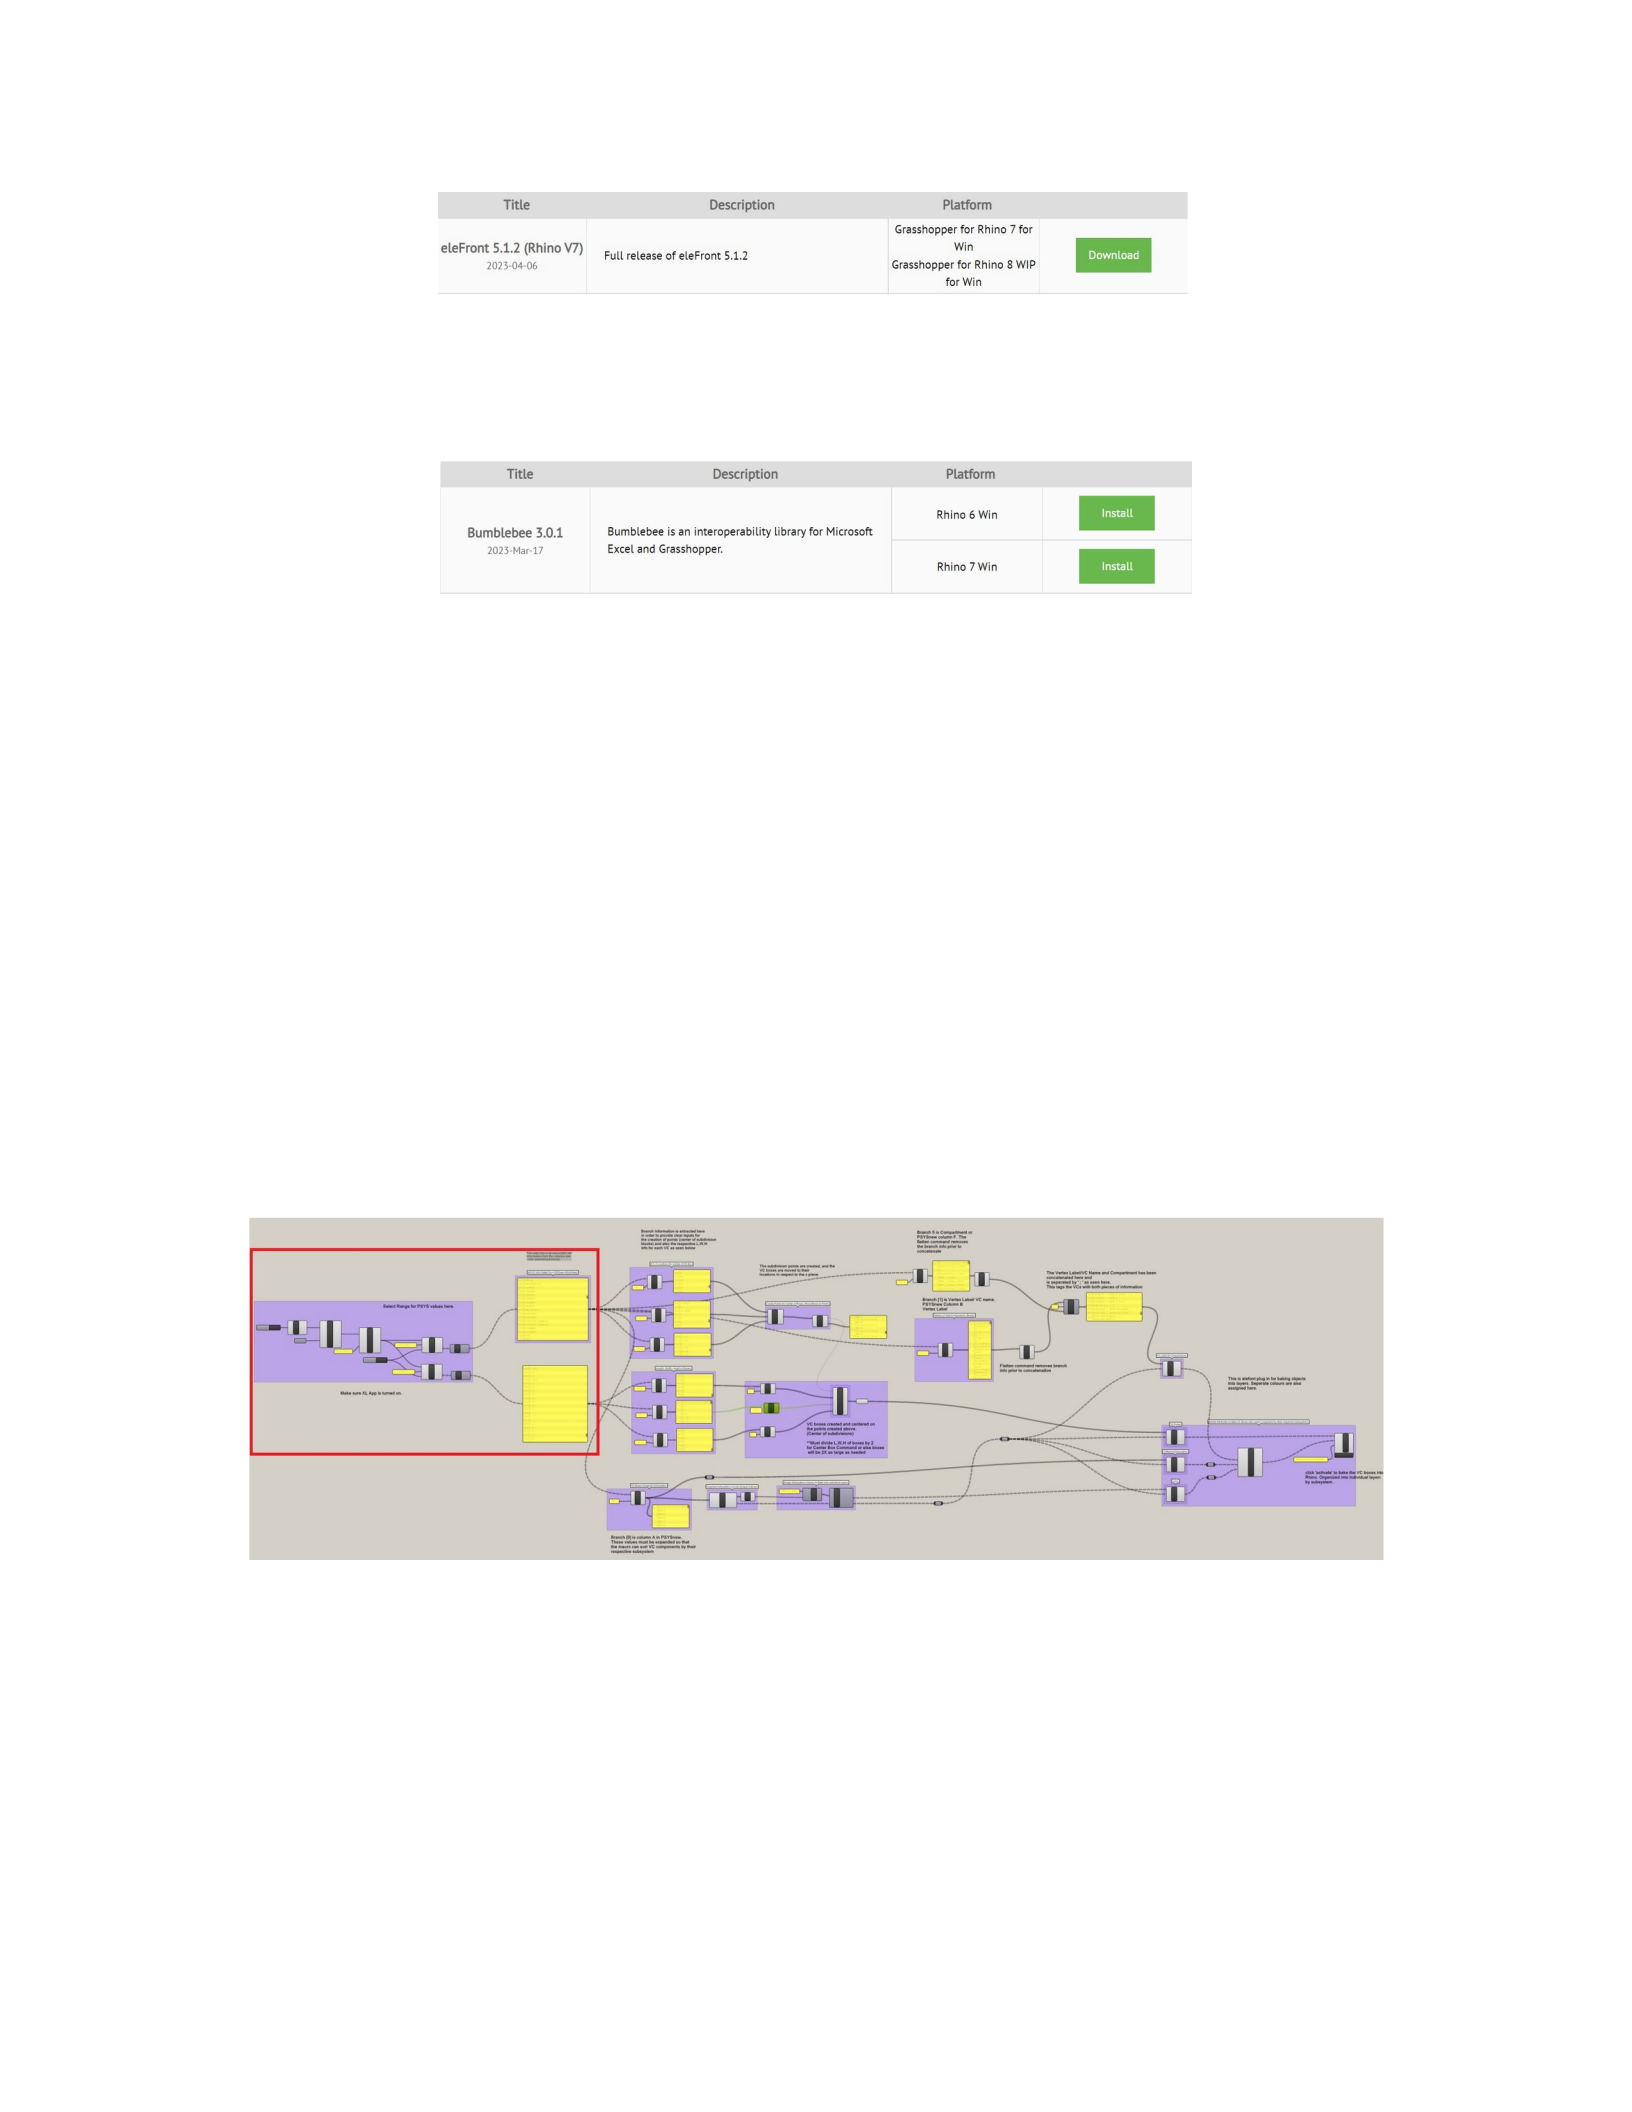
The plug-ins required to operate the initial setup tool are Elefront version 5.1.2 or
later and Bumblebee 3.0 or later. These plug-ins are updated regularly and their
capabilities are improved. The following figures are screenshots taken from the
food4Rhino website.
46
Figure A-1: Required Elefront Plug-ins
Figure A-2: Required Bumblebee Plug-ins
In Grasshopper Coding, Bumblebee reads and imports VC information from a
synthesis model that creates a data tree in Grasshopper. Elefront allows attributes
such as name, assigned compartments, and colors to be embedded with the Rhino
object, and "bakes" or makes the VC as a Rhinoceros Object that is organized into
layers and is free to move. These two plug-ins will be described further in this
appendix. The Locust Code section circled in Red as shown will now be explained
and the code block will be referenced by the numbers seen above the individual
block as seen on A-3.
Figure A-3: VC Info Read from SSM using Bumblebee
The purpose of this part of the code is to read the SSM Excel worksheet and
import all the information needed to create and deploy the VC into Grasshopper. In
the upper right corner of A-3, the icon used in Bumblebee is highlighted. There are
two ways to put new coding into Grasshopper, you can select the icon from the toolbar,
47
or you can double-click to the Grasshopper workspace which will open a small
command line where the user can type commands just like you can in Rhino. All
code blocks must be wired to flow through each other as shown.
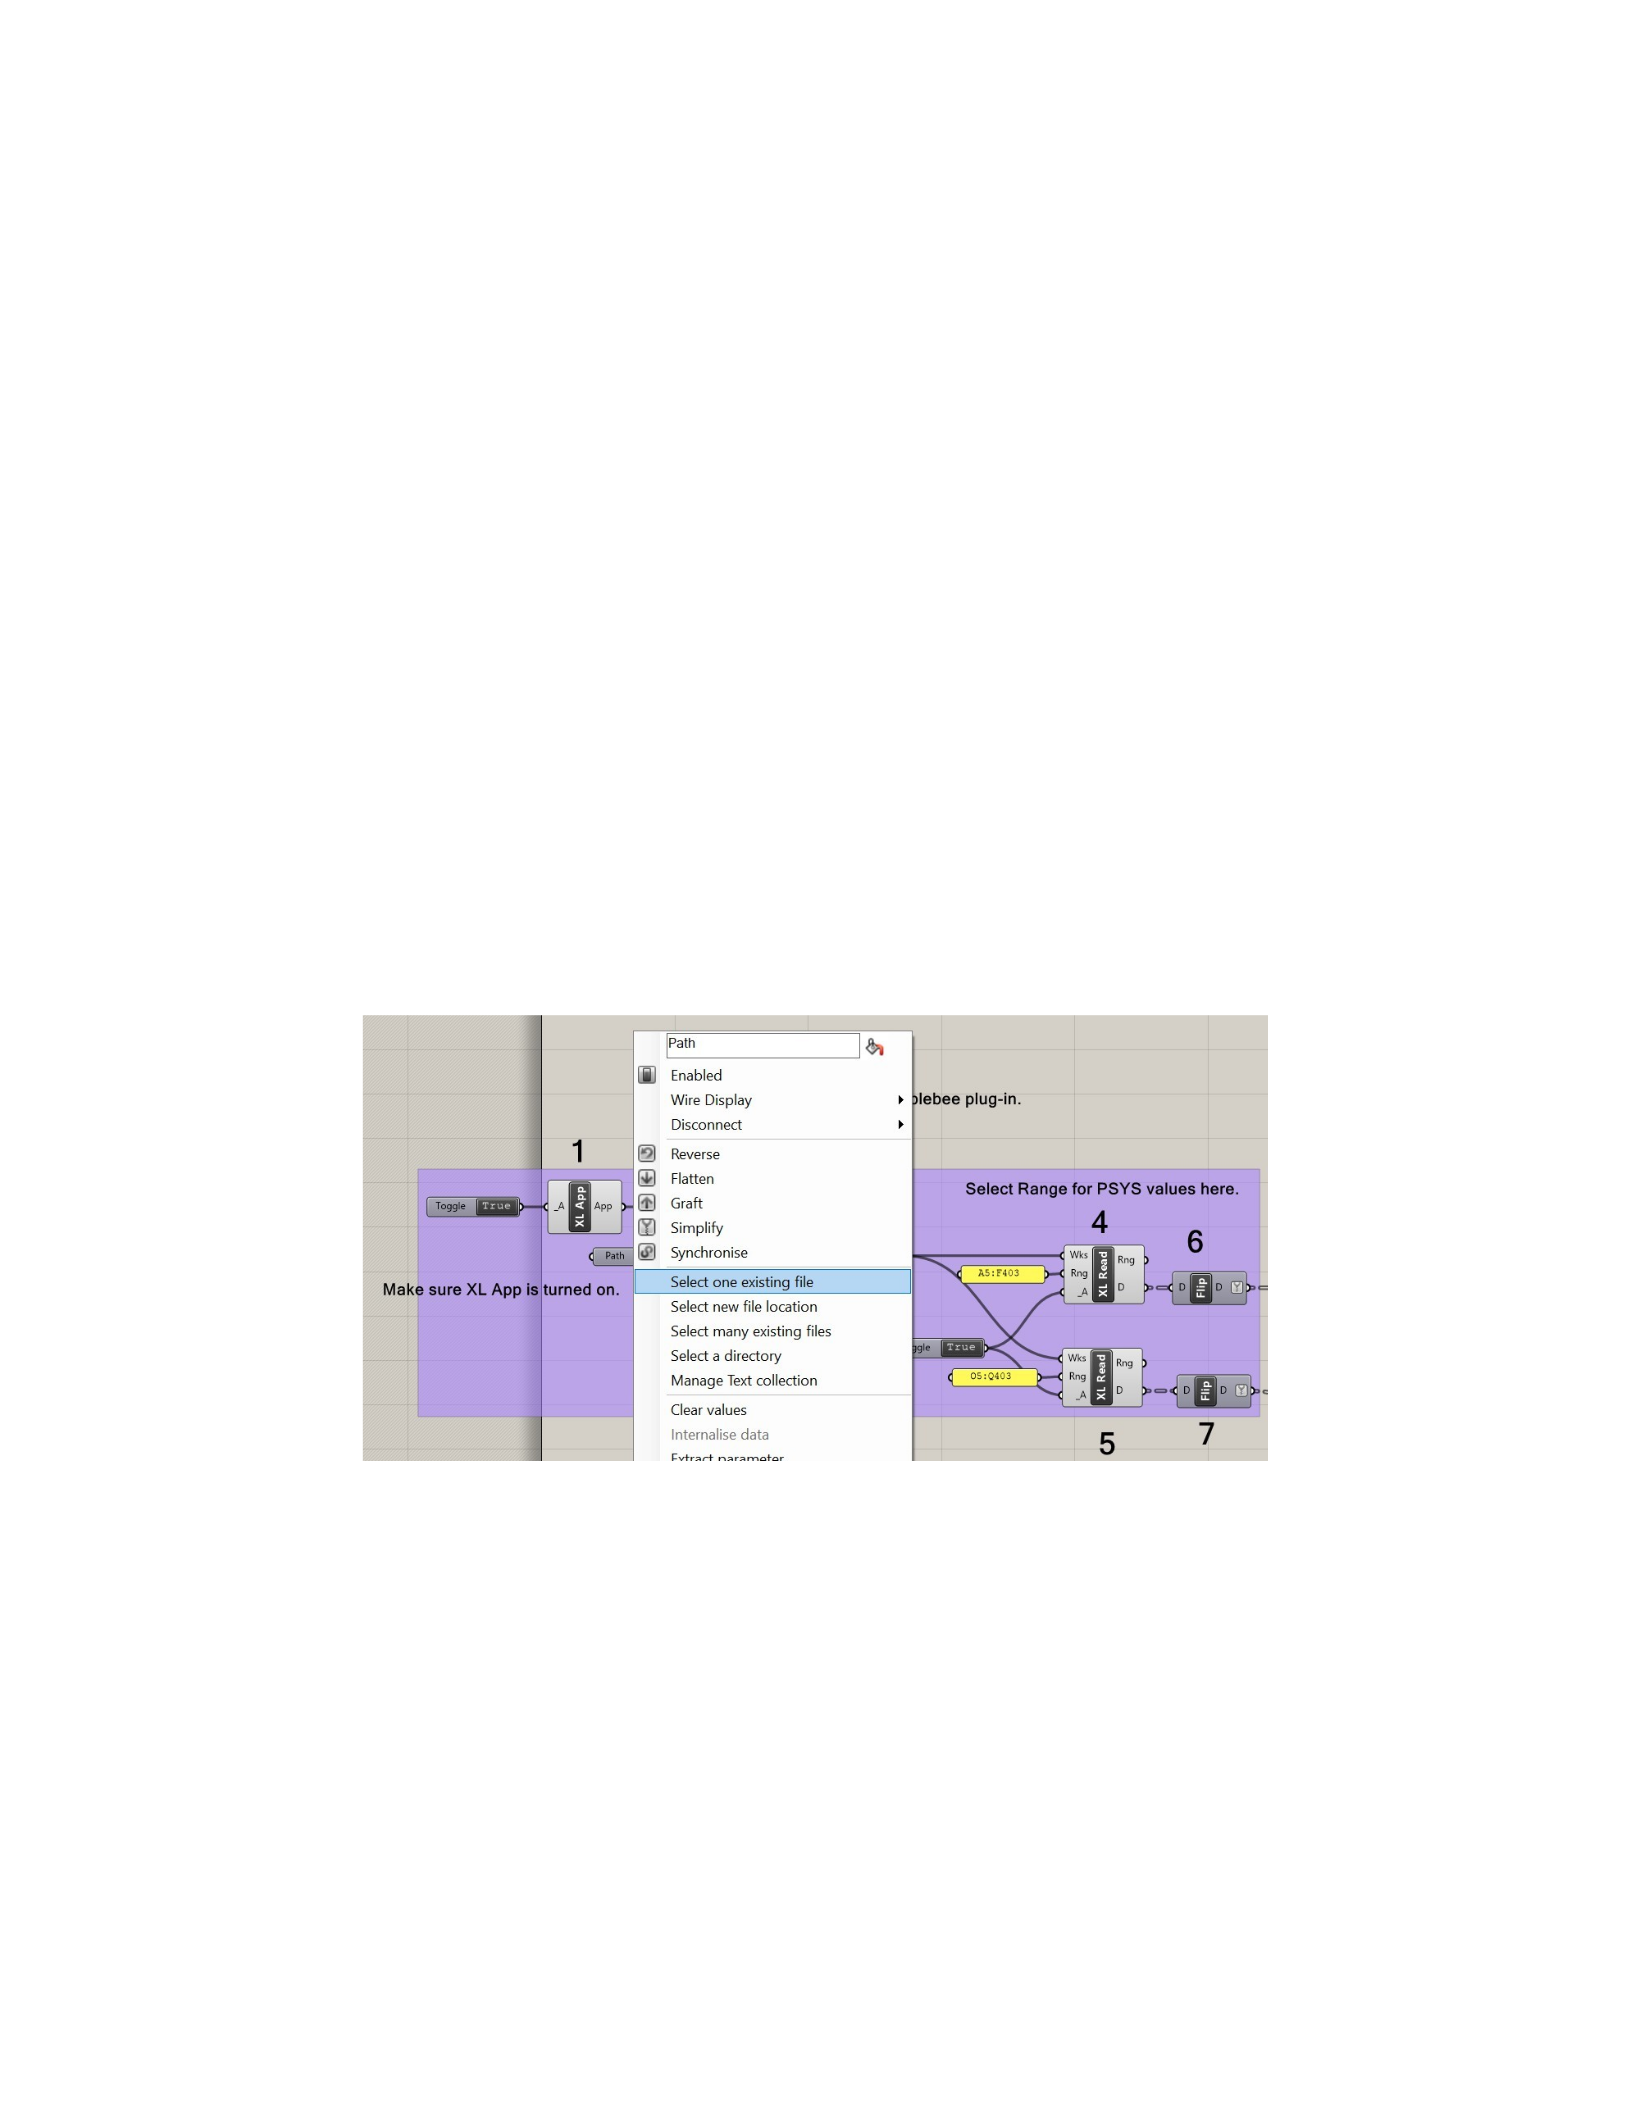
Block 1 is an Excel Application, this must be rotated by placing the Boolean =
true switch for Bumblebee to be executable. During troubleshooting situations, it
would be helpful to disable the entire app by creating the Boolean = false switch.
Block 2 is the "load workbook" command in Grasshopper (from Bumblebee).
There are two inputs to this block, Application and P. Application is an Excel
Application from block 1, and P is the path of the file and there is a small block
labeled Path next to the input P. This is created using the "path" command in
Grasshopper. By right-clicking on this Path block, a single file can be selected from
anywhere in the user directory. This file path needs to be traced to SSM in the exact
location where it is stored and it is important to be careful with version control in
SSM that is updated or moved in the directory.
Figure A-4: Tracing the File Path to SSM
Now that the file path to SSM is entered, block 3 is the "Get Worksheet"
command in Grasshopper (from Bumblebee). The input to this block is "Wbk"
(workbook) which is connected to the output of Block 2 (reading the entire SSM)
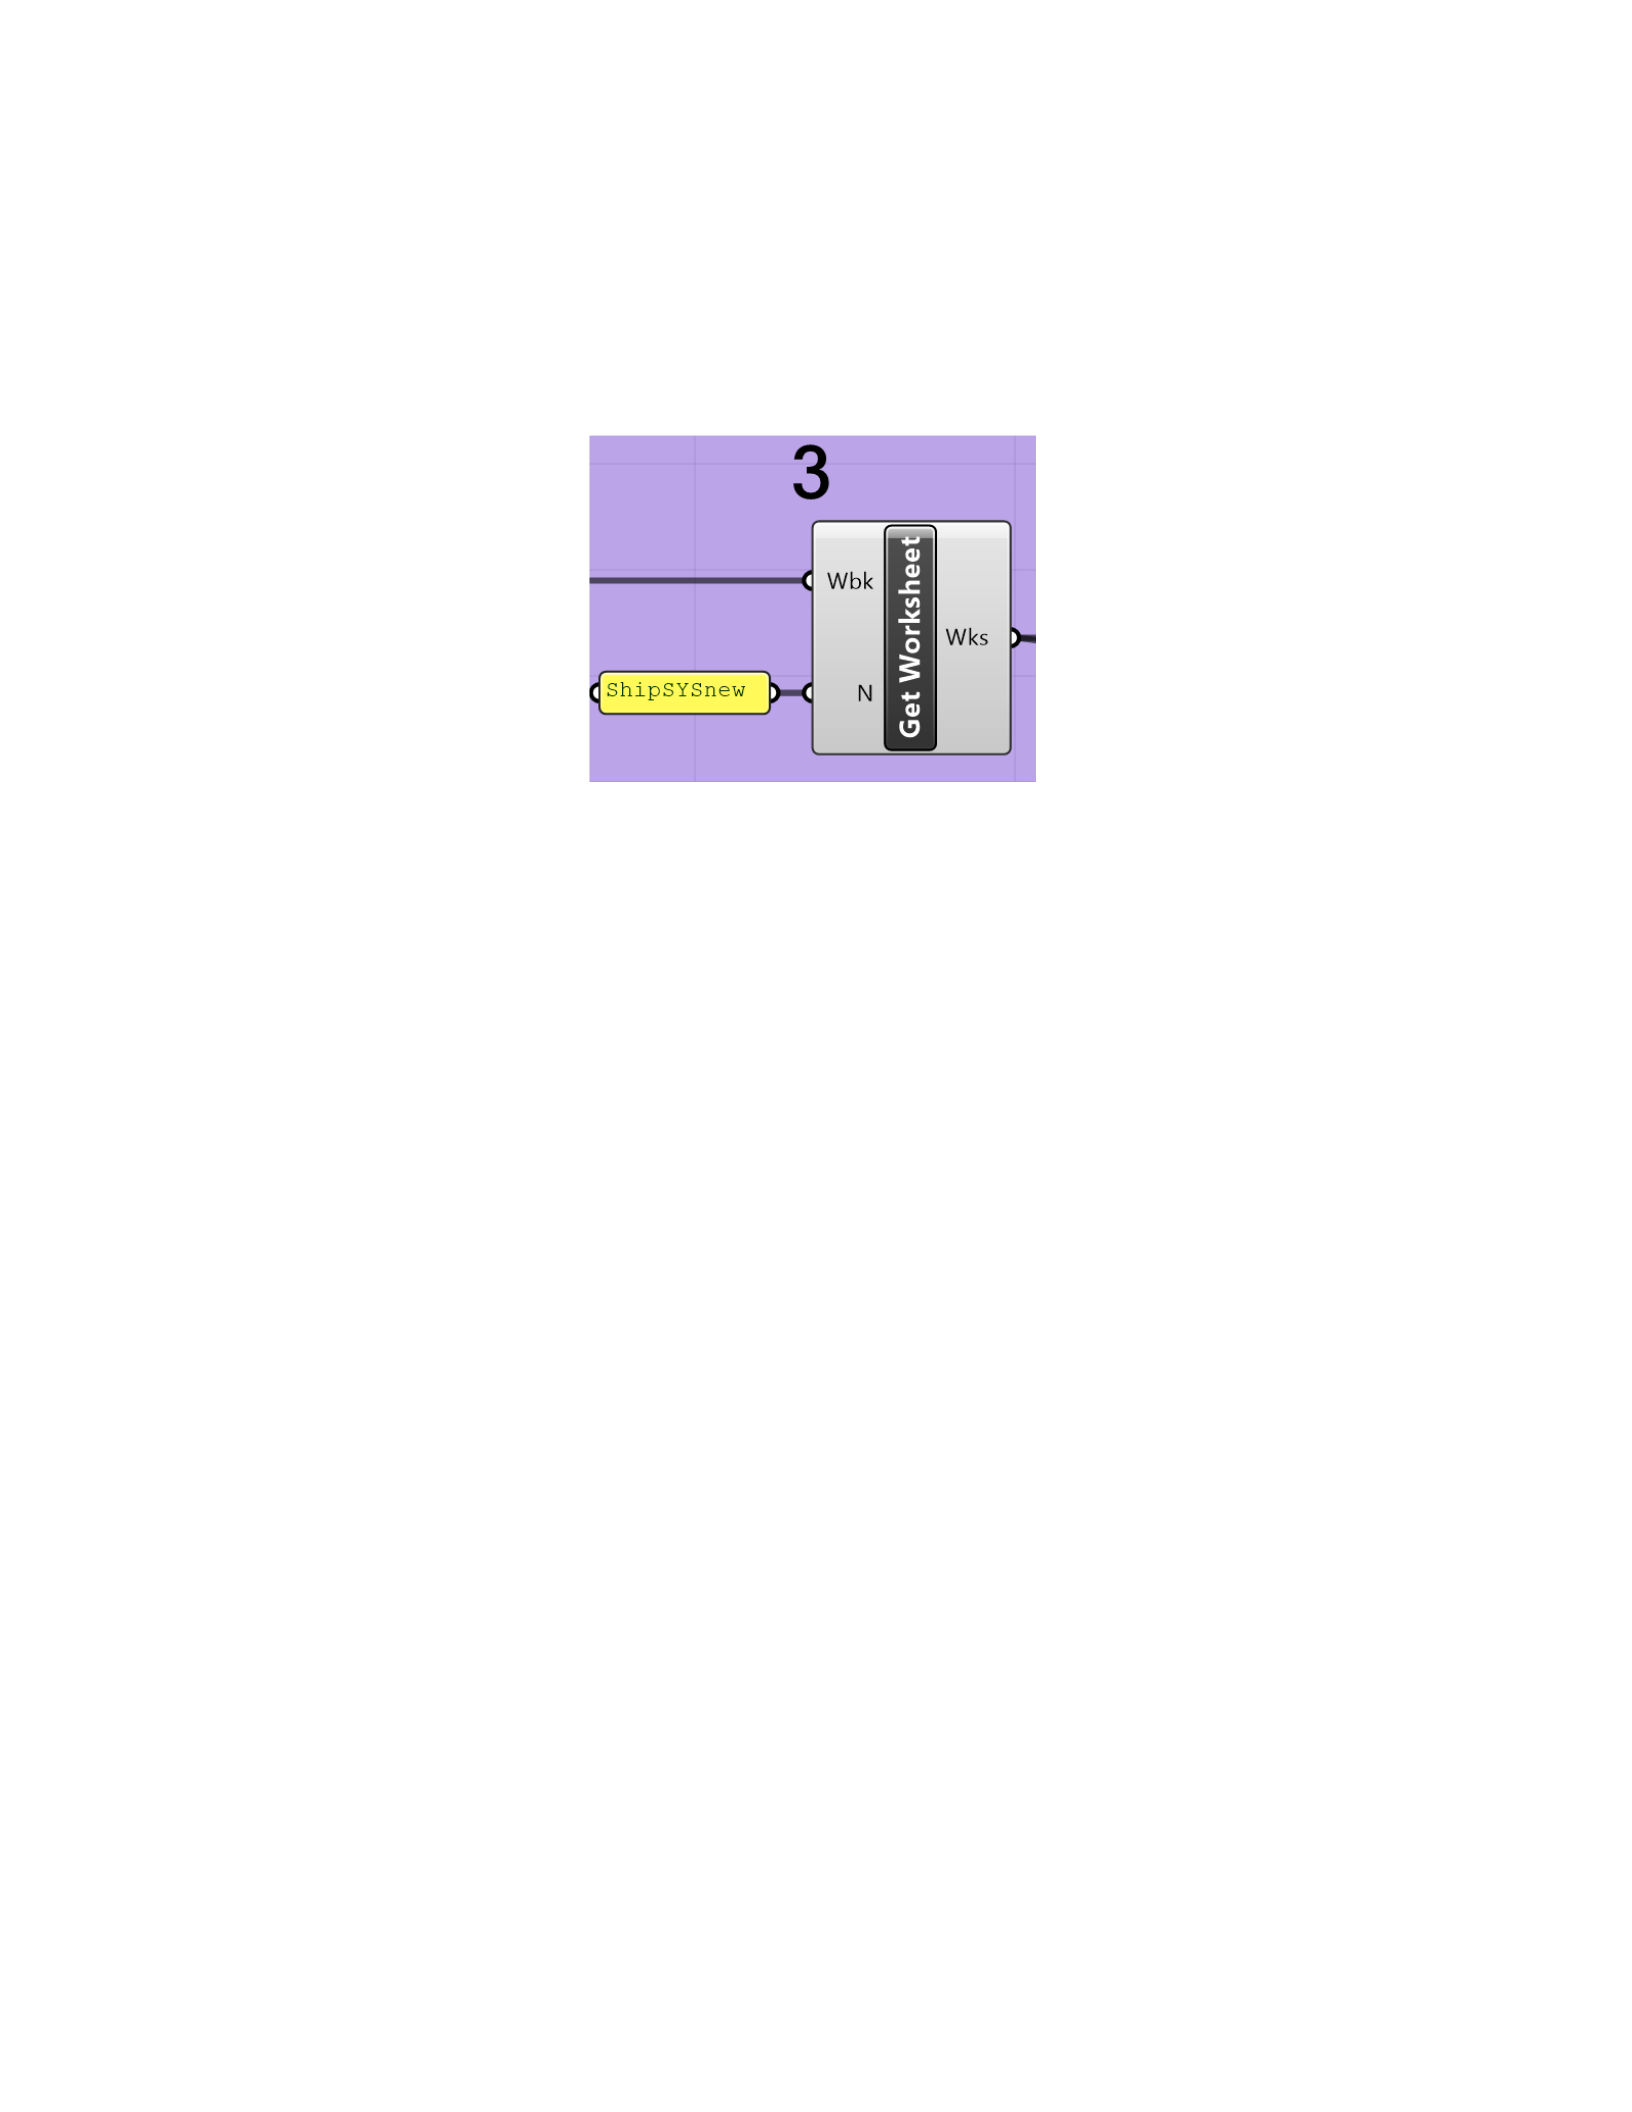
48
and "N" (worksheet). This block reads specific Excel worksheets from SSM as
desired. To capture all the VC info, a ShipSYSnew worksheet is desired. A panel is
created, and the exact format of the ShipSYSnew text is copied from the Excel tab
that contains the worksheet name, placed into this panel, and connected to N.
Figure A-5: ShipSYSnew Worksheet from SSM Read by the Locust Panel
placed on the output of each Locust code block will show you
The current state of the data sent to the next block. This is a very useful way to build
tools and ensure that the desired information is connected to the appropriate inputs
for other blocks of code.
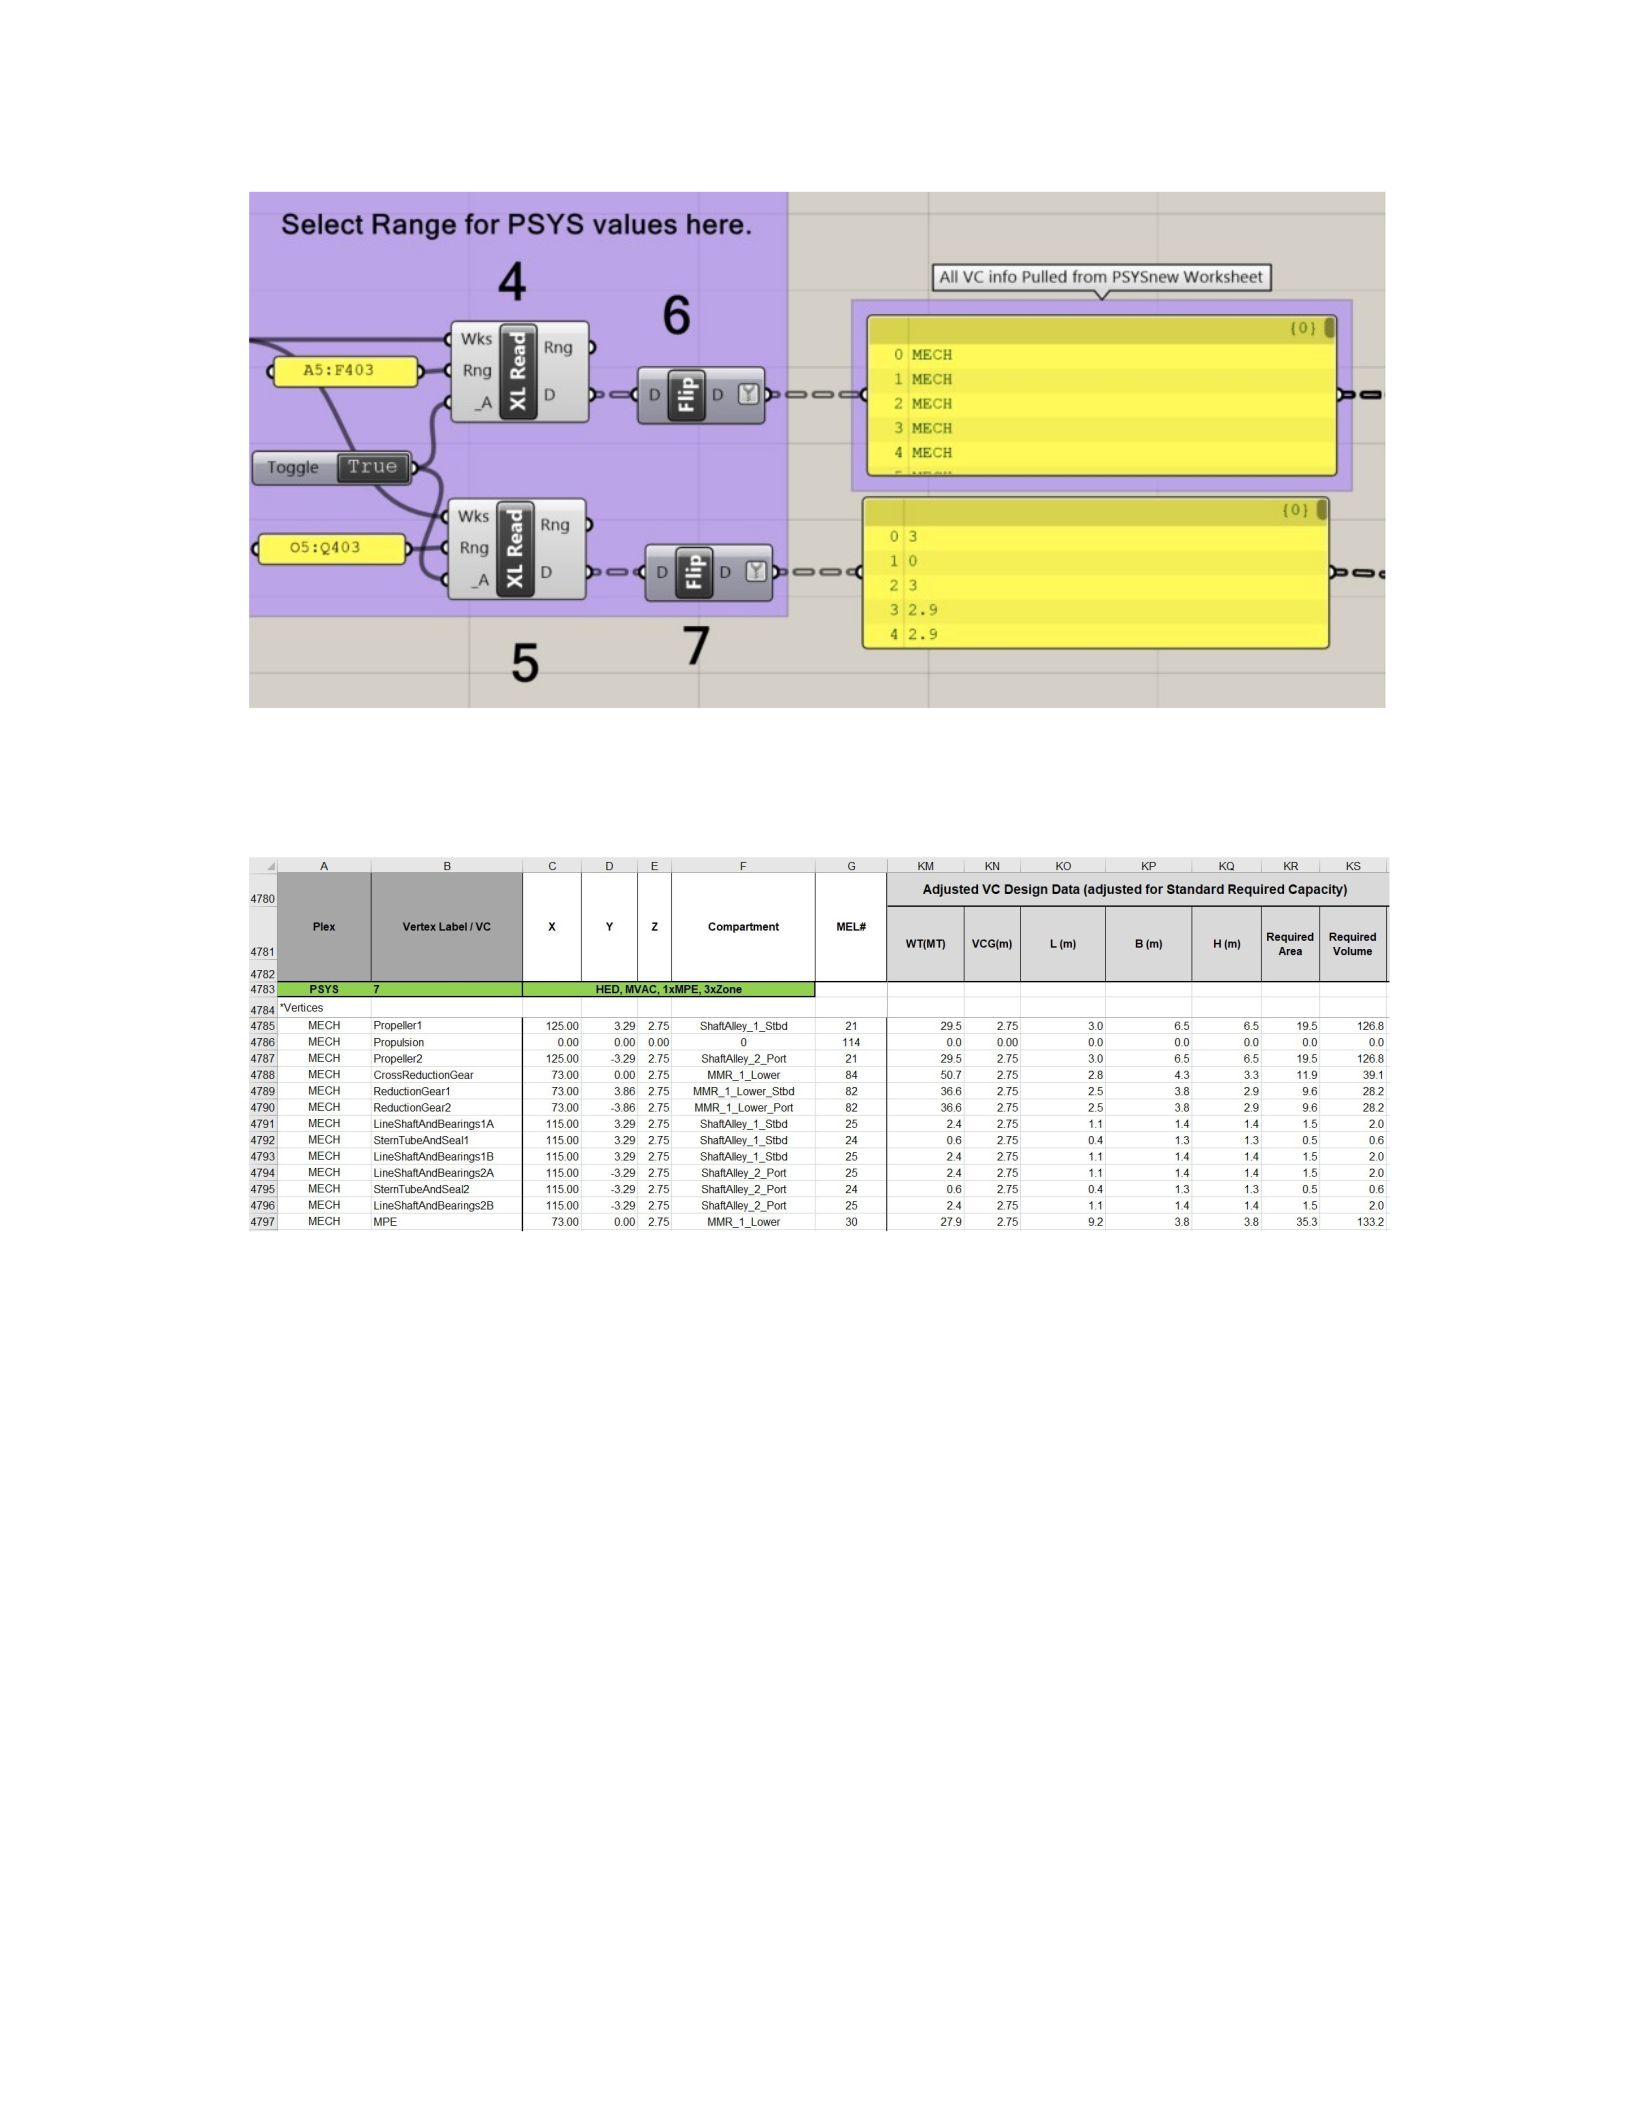
Blocks 4 and 5 are the "Read Excel" command in Grasshopper. These two blocks
are used to extract all the necessary VC information from SSM and import it into
Grasshopper. Block 4 is used to read Columns A to F of the new ShipSYS tab of
SSM.
49
Figure A-6: AF Column, and KO-KQ Imported into Locust
Table A.1: VC information required from SSM
As you can see in figure A-6, Block 3 should be connected to Block 4 and Block
5. The Boolean toggle for each block must also be equal to "True". Input -A in a
block refers to the exact range of Excel Cells that the code will read. In this case,
Block 4 reads all the values from SSM From cell A5 to cell F403. Block 5 reads all
cells from O5 to Q403.
Blocks 6 and 7 are "flip" commands that place the data into the correct format to
be organized into the data tree. It can be thought of as swapping rows and columns
into matrix-like data. The panel on the right shows the output from Block 4 and
Block 5. This pane is a data tree that contains all the imported Excel information, and
its branches are organized by Excel data columns. In the top right corner
50
from the panel, 0 is displayed. This indicates that the first column of Excel
information is labeled zero and as you can see is the plex information contained in
the Excel column
A. It is important to remember that the first branch in all Locust data trees is labeled
as zero. After completing this step, all the information needed to create the VC is
loaded into Grasshopper and can be used for other commands. It is also possible to
right-click on the XL reader and select "internalize data" which saves the data into
the locust worksheet itself and no longer requires SSM to find the data. This is useful
for times when it may be desirable to send Grasshopper code to other users who may
not have access to SSM.
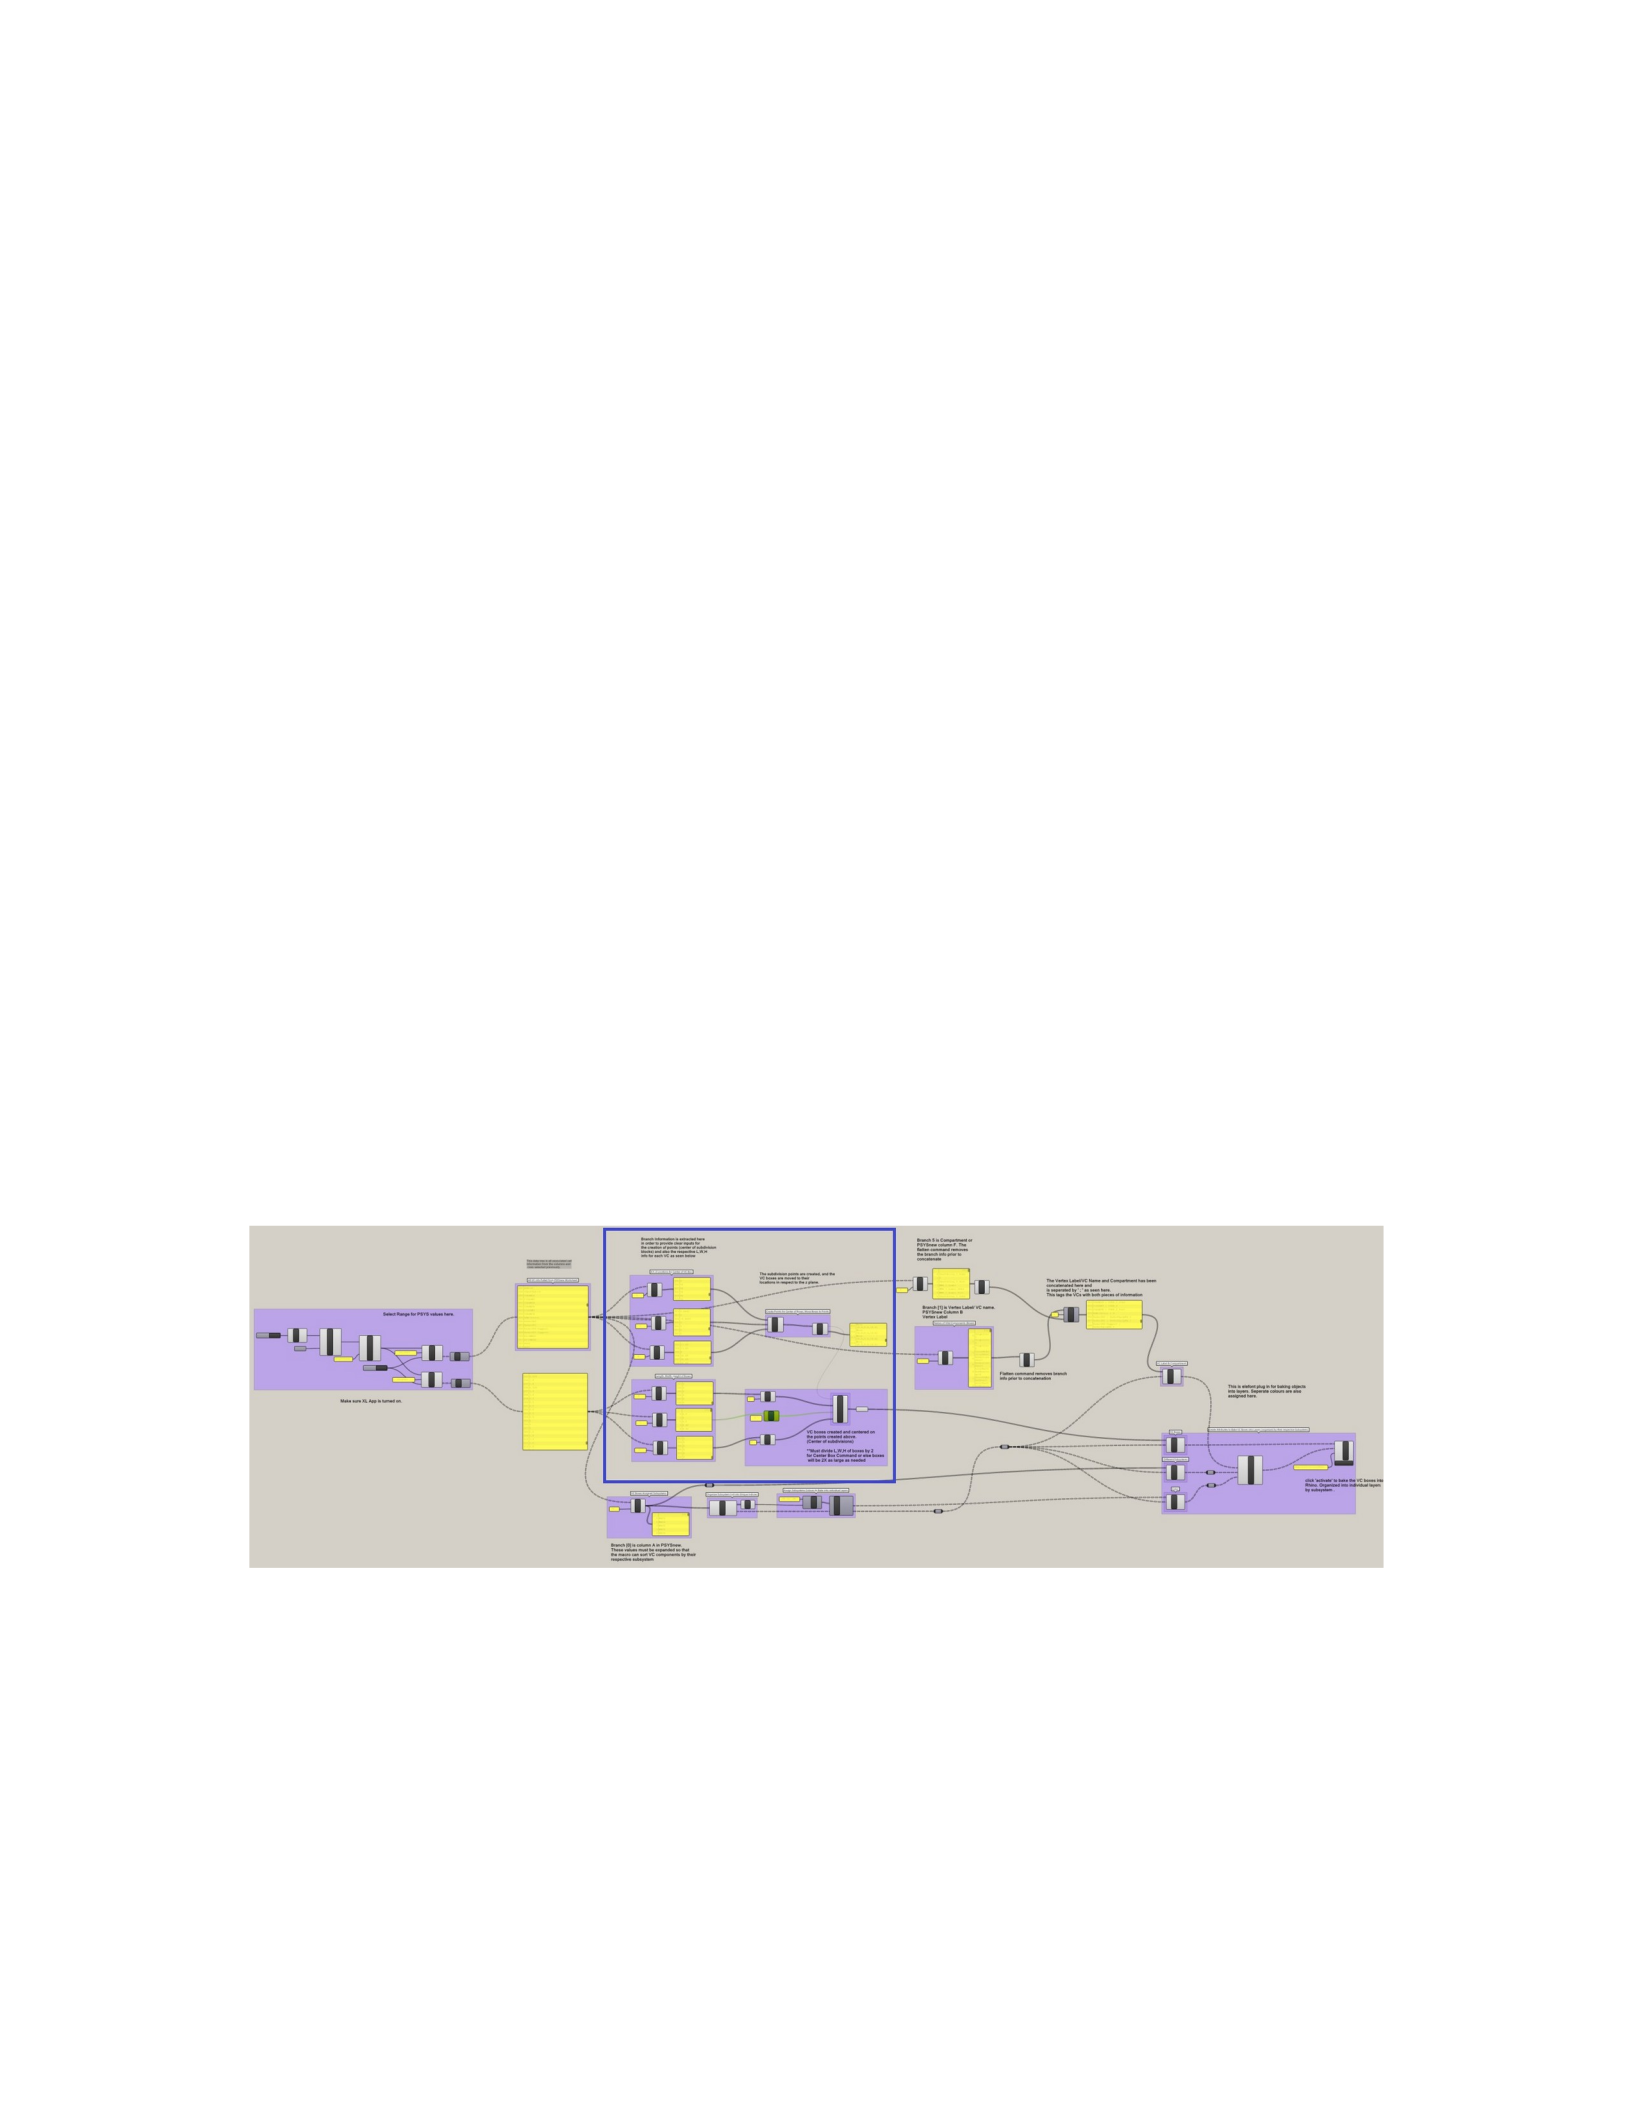
A.1
Creating and Placing Critical Components Boxes
The following details describe the part of the locust code circled in blue as shown
below in figure A-8. I n t h i s s e c t i o n o f c o d e , e a c h b r a n c h o f
i n f o r m a t i o n i s e x t r a c t e d f r o m a d a t a t r e e i m p o r t e d f r o m S S M
u s i n g a n X L r e a d e r . A b o x r e p r e s e n t i n g t h e V C a n d a d o t
r e p r e s e n t i n g t h e c e n t e r o f t h e s u b d i v i s i o n b l o c k a r e c r e a t e d .
Figure A-7: Locust Code for Creating and Placing VCs (circled in blue)
In this section of code, each branch of information is extracted from a data tree
imported from SSM using an XL reader.
51
Figure A-8: Locust Code for Creating and Placing VCs
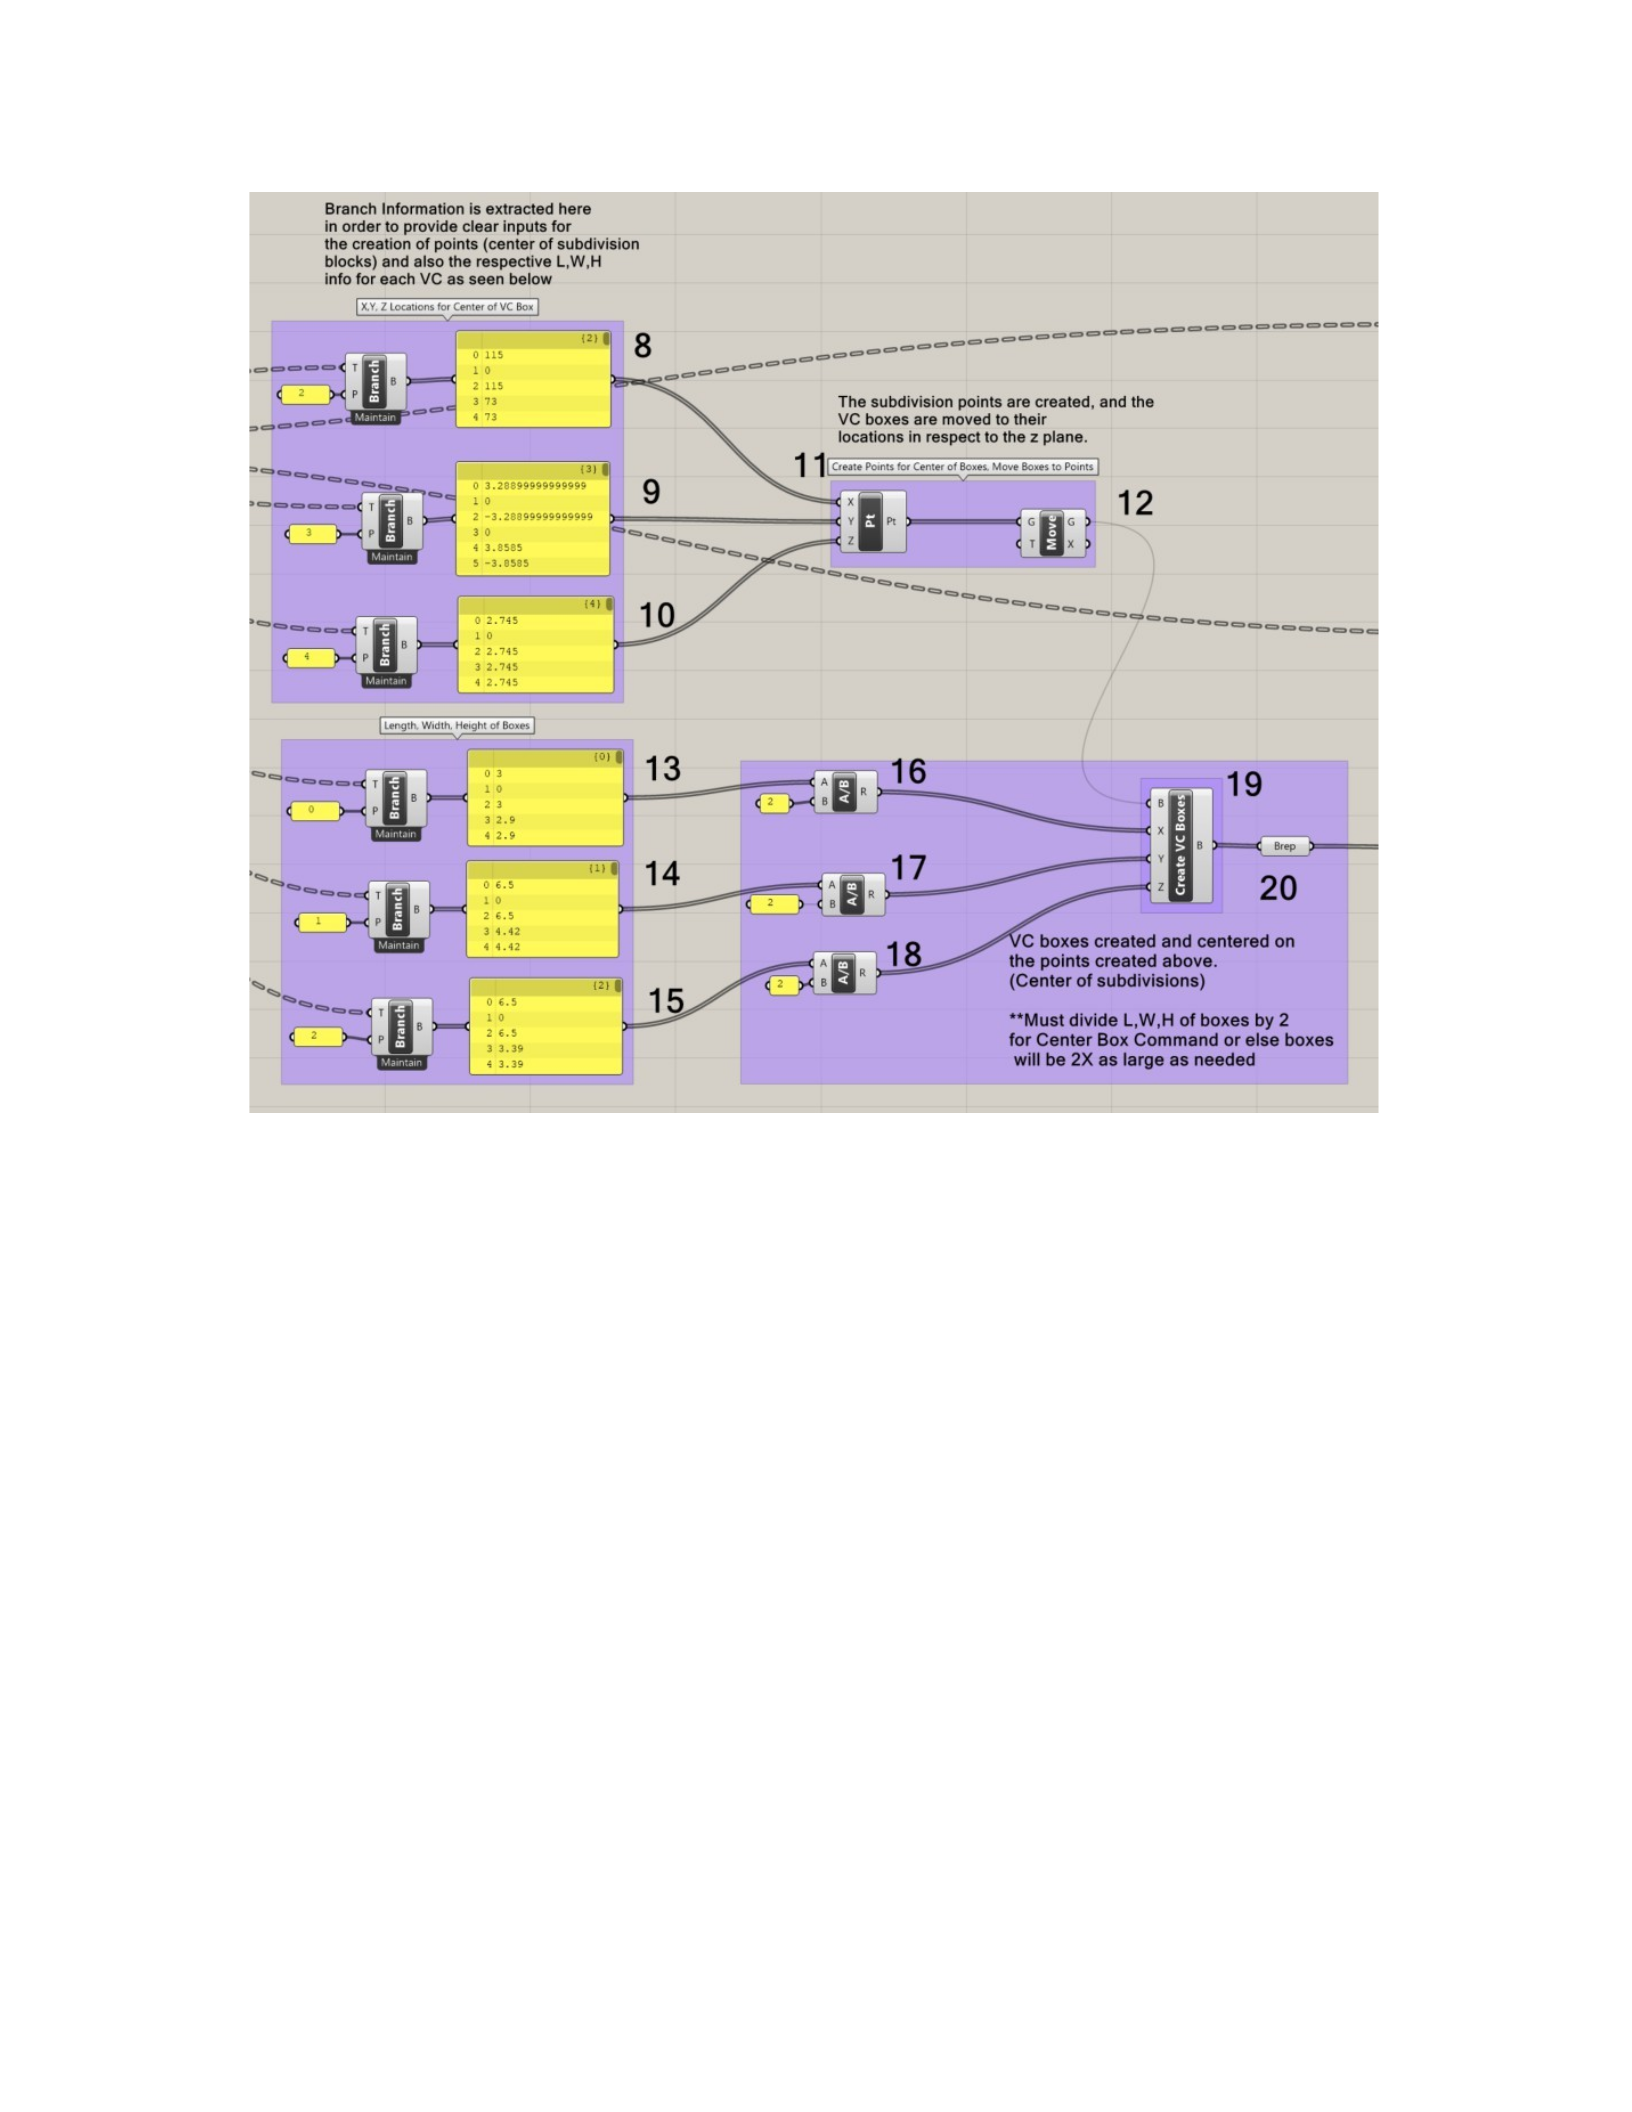
Blocks 8-10 show the branch information extracted from the first data tree of
excel data imported from SSM. Block 8 has branch 2 which is location X for the
center of the subdivision block, and blocks 9 and 10 are locations Y and Z for the
center of the subdivision block. These branches are incorporated into Block 11 which
is the "Create Points" command in Grasshopper. It is the red cross seen in the
Rhinoceros display port, and is the centroid of all subdivision blocks. Blocks 13-15
are individual branches of the second data tree imported from the second range of
excel values which are X, y, and Z dimension information to create the VC box. This
data is plugged into block 19 which is the "Middle Box" Locust Command and has
been renamed to "Create VC Box" for the purposes of this tool. Blocks 16-18 are the
mathematical operators that divide the dimensions
52
information from blocks 13-15 becomes two. This is necessary because the "Middle
box" command will make the Rhino object twice as large as desired because the
dimensional information is measured from the center of the box.
Block 20 is the Locust's command "Brep", which designates the newly created
box as a (Boundary Representation) that can later be converted into a Rhinoceros
object. Block 12 is the Locust Command "Move". It is connected to block 19 as
shown, which moves the center of the box to the point created by block 11. This is
how VC objects are placed in the appropriate location and why many VCs are placed
on top of each other. In this Code of Locusts, 399 boxes are created by block 19, and
399 moves are executed by block 12. The information in each panel other than
blocks 8-10 and 13-15 is numbered 0-398 for a total of 399 values listed in each
panel. By checking this, users can be sure that all VCs have been taken into account.
A.2
Assigning Attributes to Rhino VC Objects
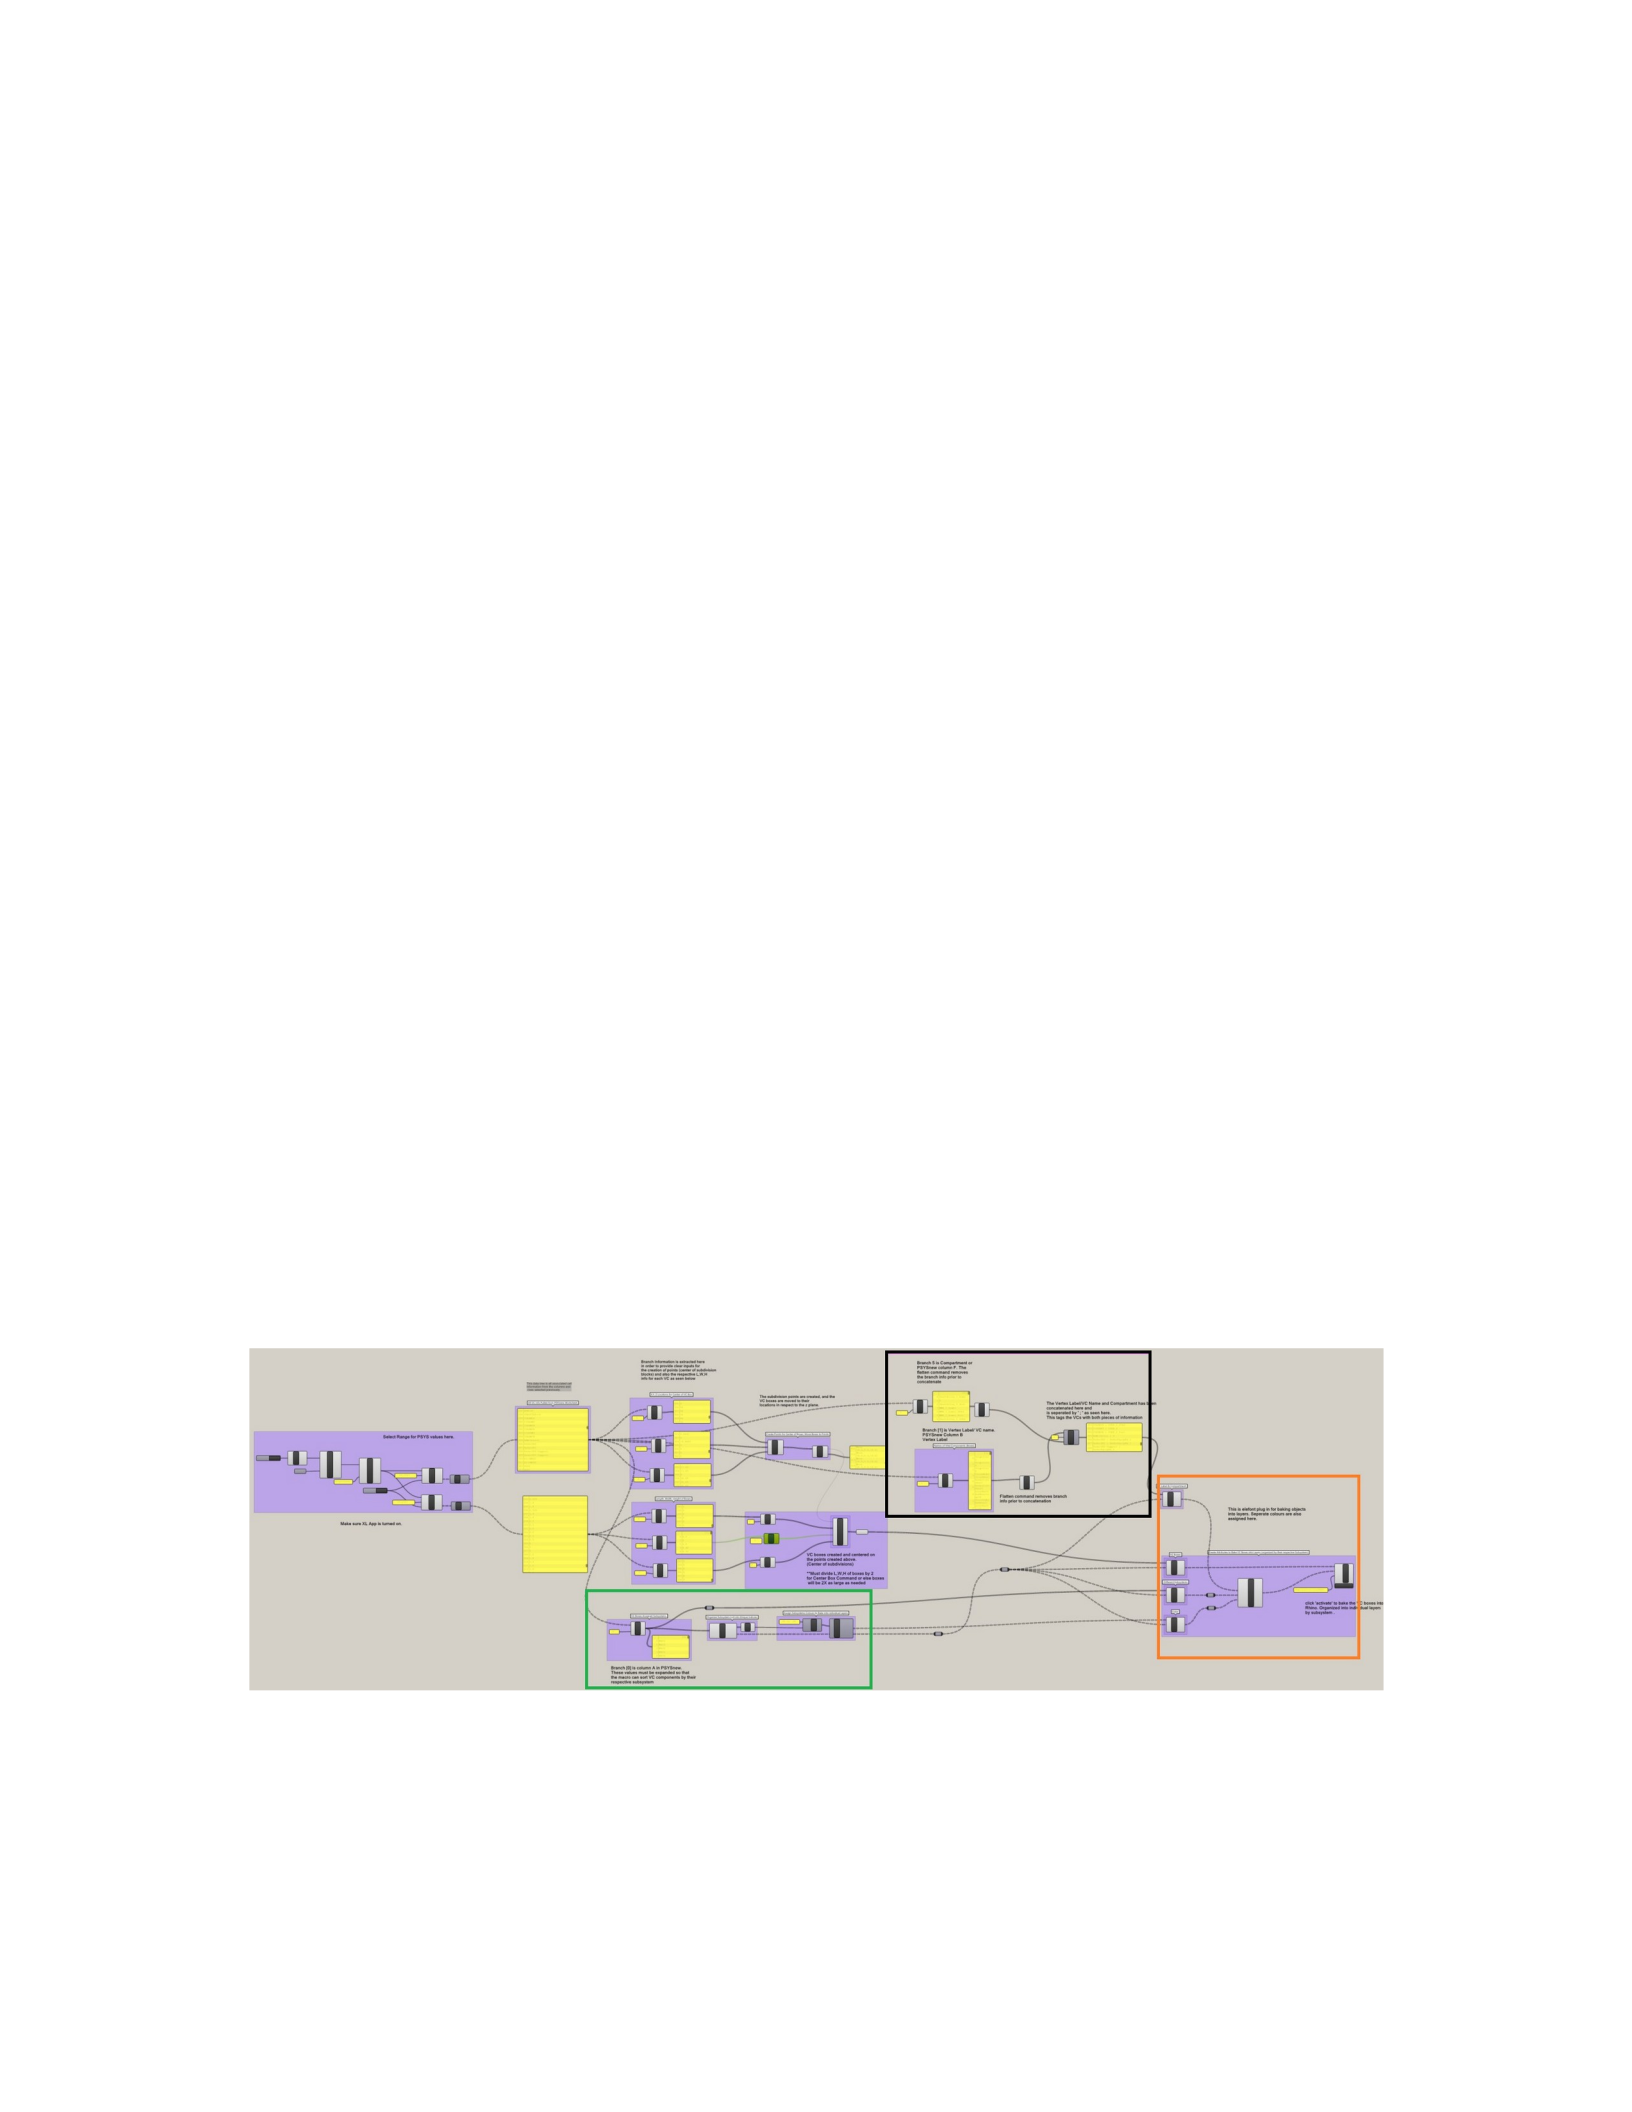
The Locust Code circled with Green, Black, and Orange is described in this section.
This part of the code assigns the attribute (information) to the VC box that has been
created. The end result is that the VC is "baked" into Rhino as a Rhino object (orange
part), with a layer and color assigned (Green Part), and an assigned node name and
compartment information (black part).
Figure A-9: Locust Code for Assigning Attributes to Rhino Objects
This description now focuses on the part circled in Green that creates the indi-
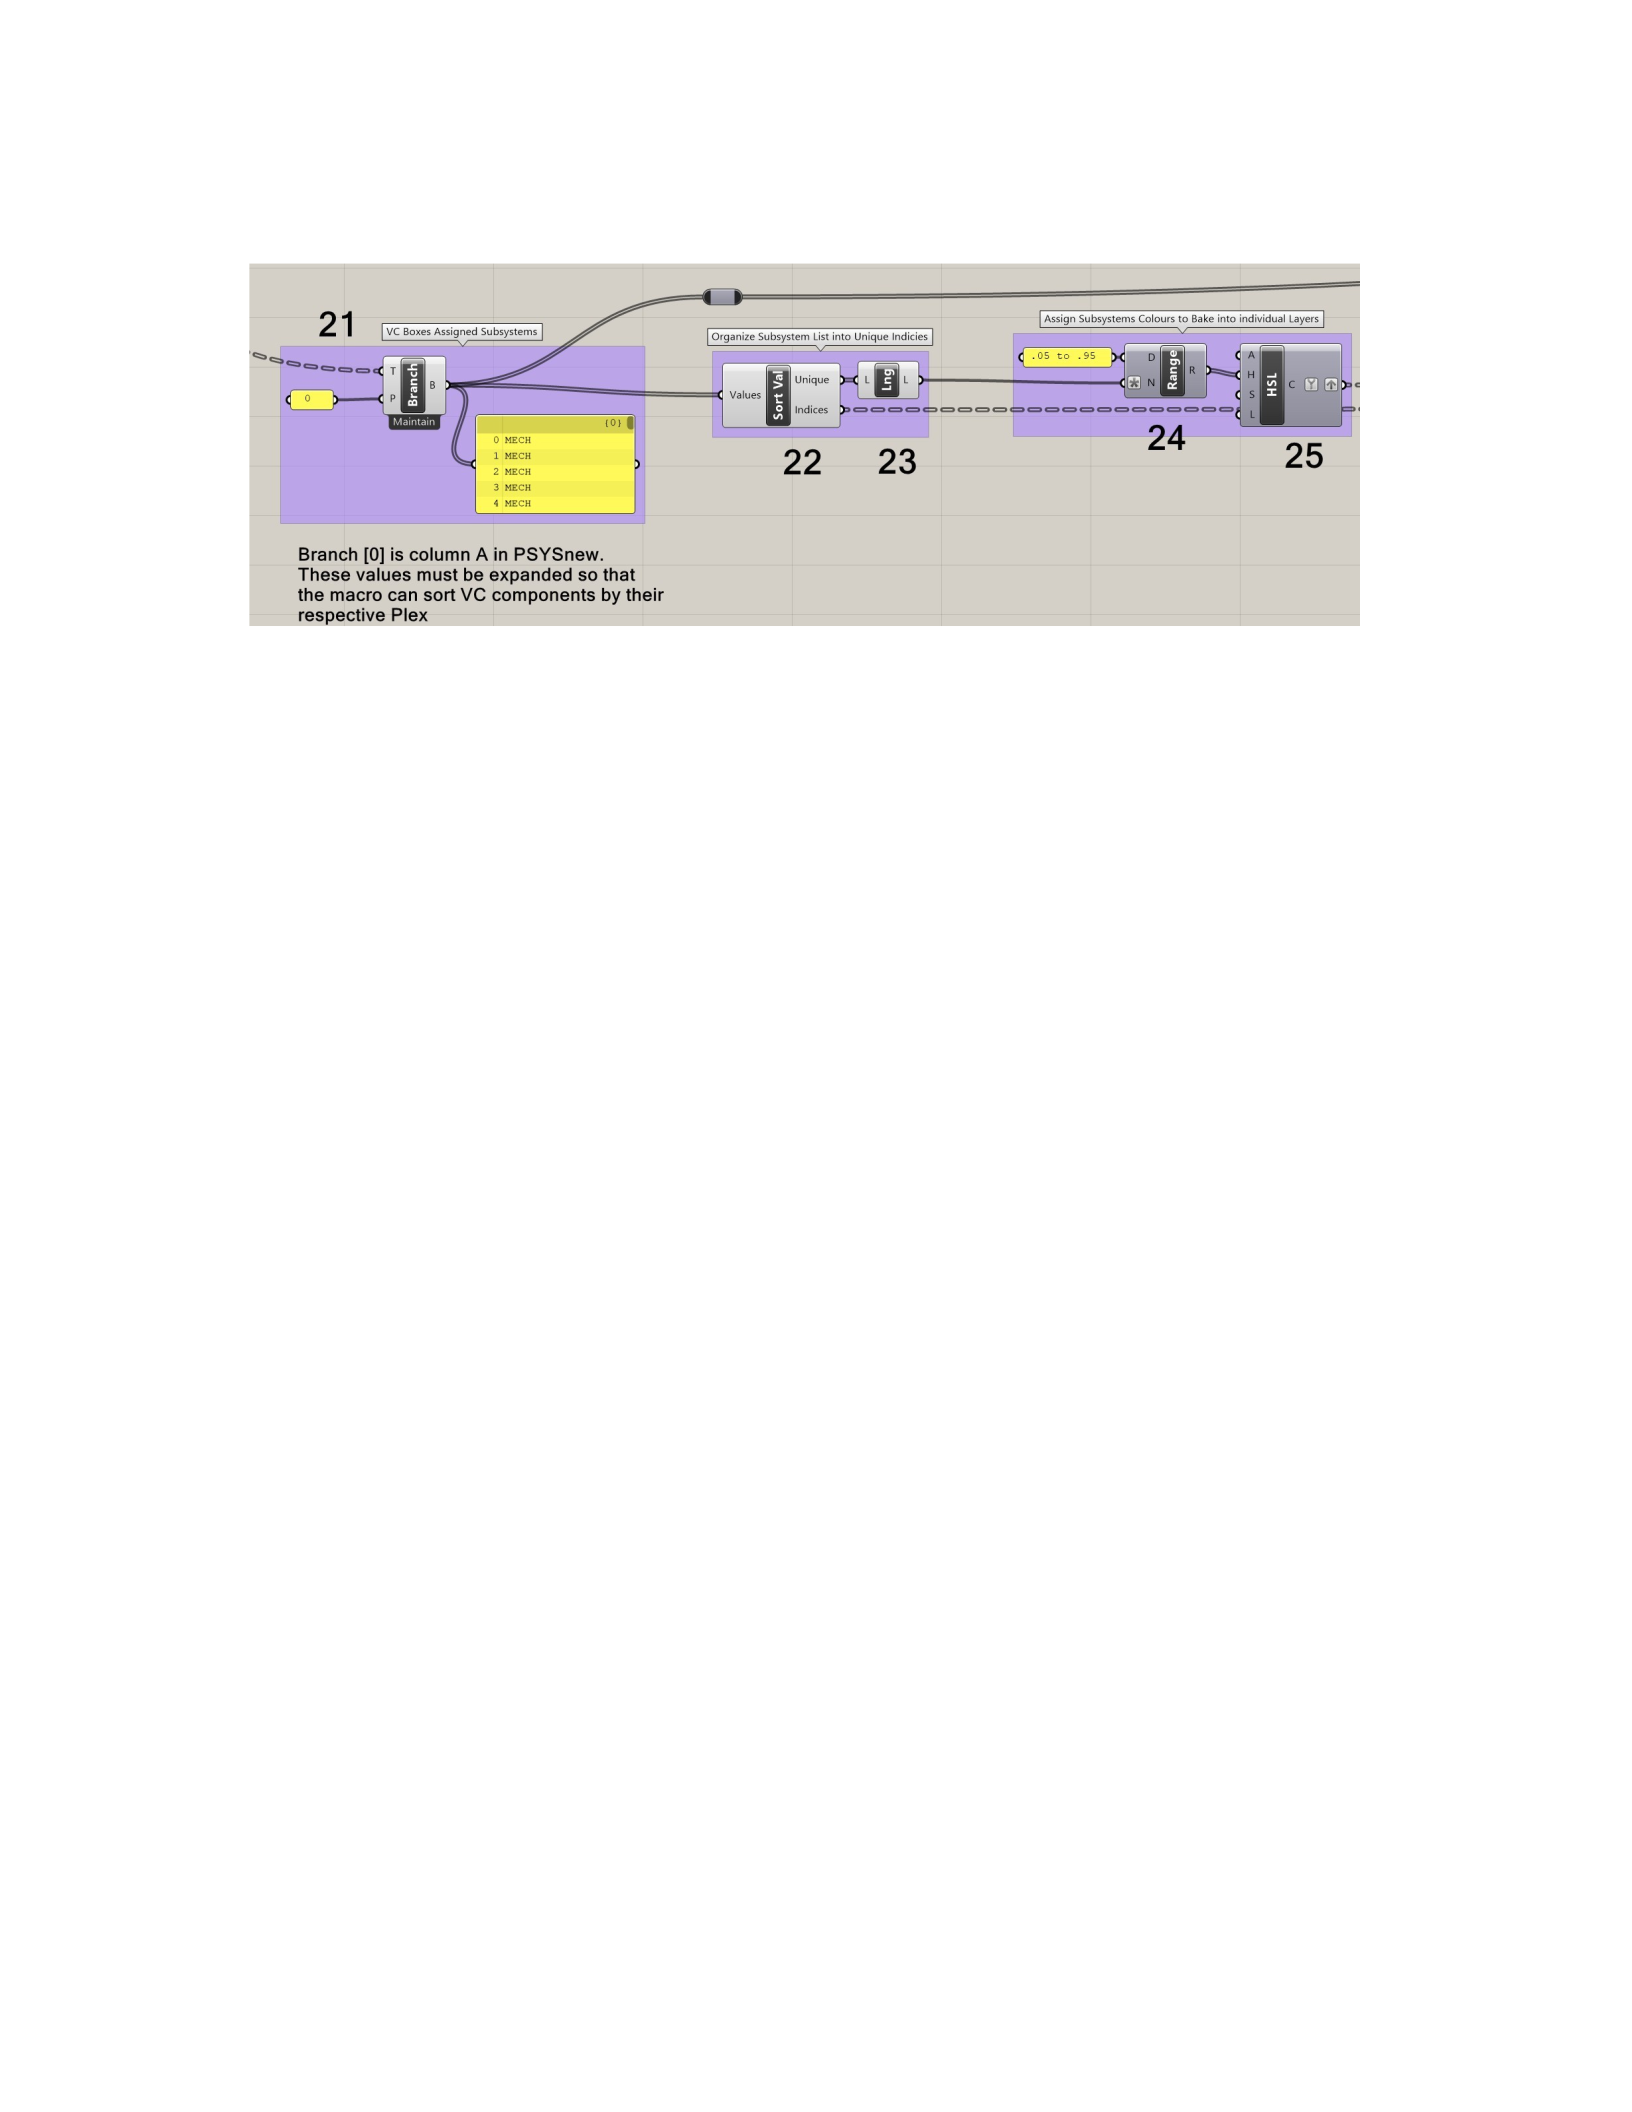
53
vidual layer set by Plex for each VC, imported from the previous SSM.
Figure A-10: Locust Code for Creating and Organizing Rhino Layer Block 21
shown above is a branch extracted from the original data tree. Ini
according to column A of the ShipSYSnew tab in SSM (Plex). The panel on the right
shows the extracted plex information. The relay wire is connected from block 21 and
runs over blocks 21-25, this will be explained further in the last section of the Locust
code. Block 22 is the Locust command "Sort Duplicate Values". What this command
does is read the branch information to the left, and set the number of unique values
present. In this case, the number of unique values is equal to the number of different
Plexes that can be found in SSM. Block 23 is the Locust command "List Length",
which calculates the number of values in the list. This gives the number of individual
plexes present, which in this case is 18. Figure A-11 below shows the output panel
placed next to blocks 22 and 23.
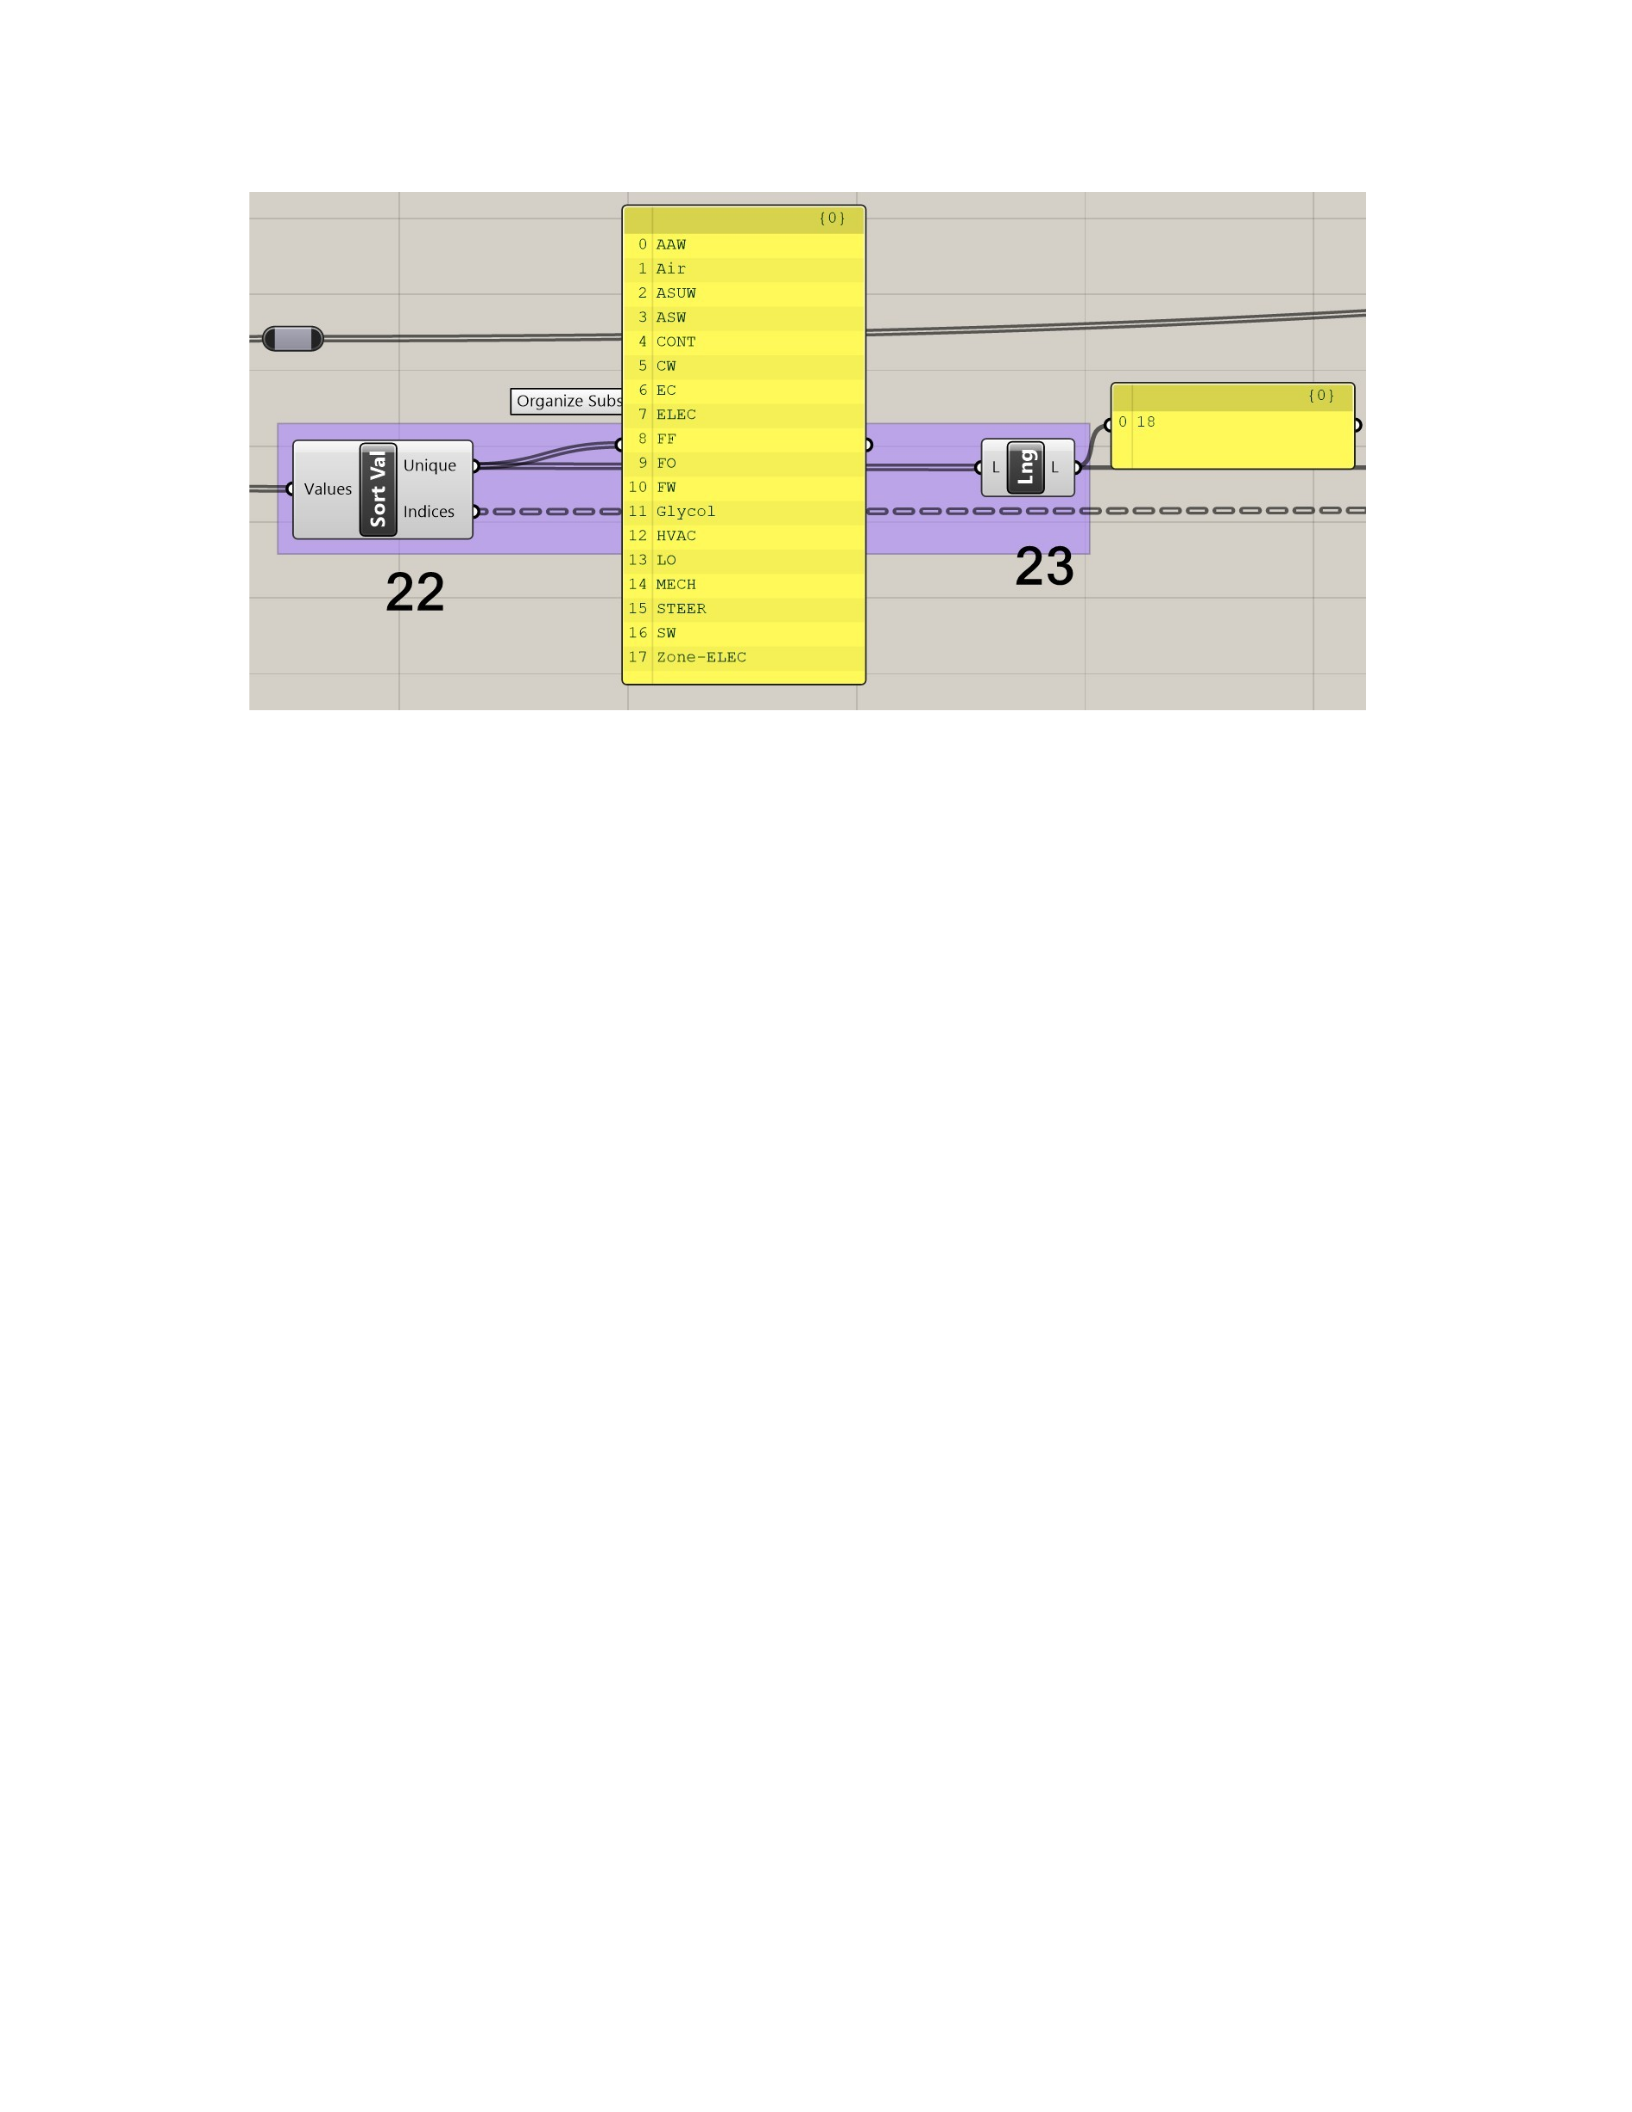
54
Figure A-11: Plex Information Organized to Create Individual Layers Blocks
24 and 25 assign a color (color) to each plex. Colors are carried out-
Domly is selected from a range of 0.05 to 0.95 and is attached to each unique plex.
These colors can be changed to the user's preferences later in Rhino. The purpose of
this section is to set the color so that when VCs are loaded into Rhino, they don't all
have the same color, which will be grayed out by default in Rhino.
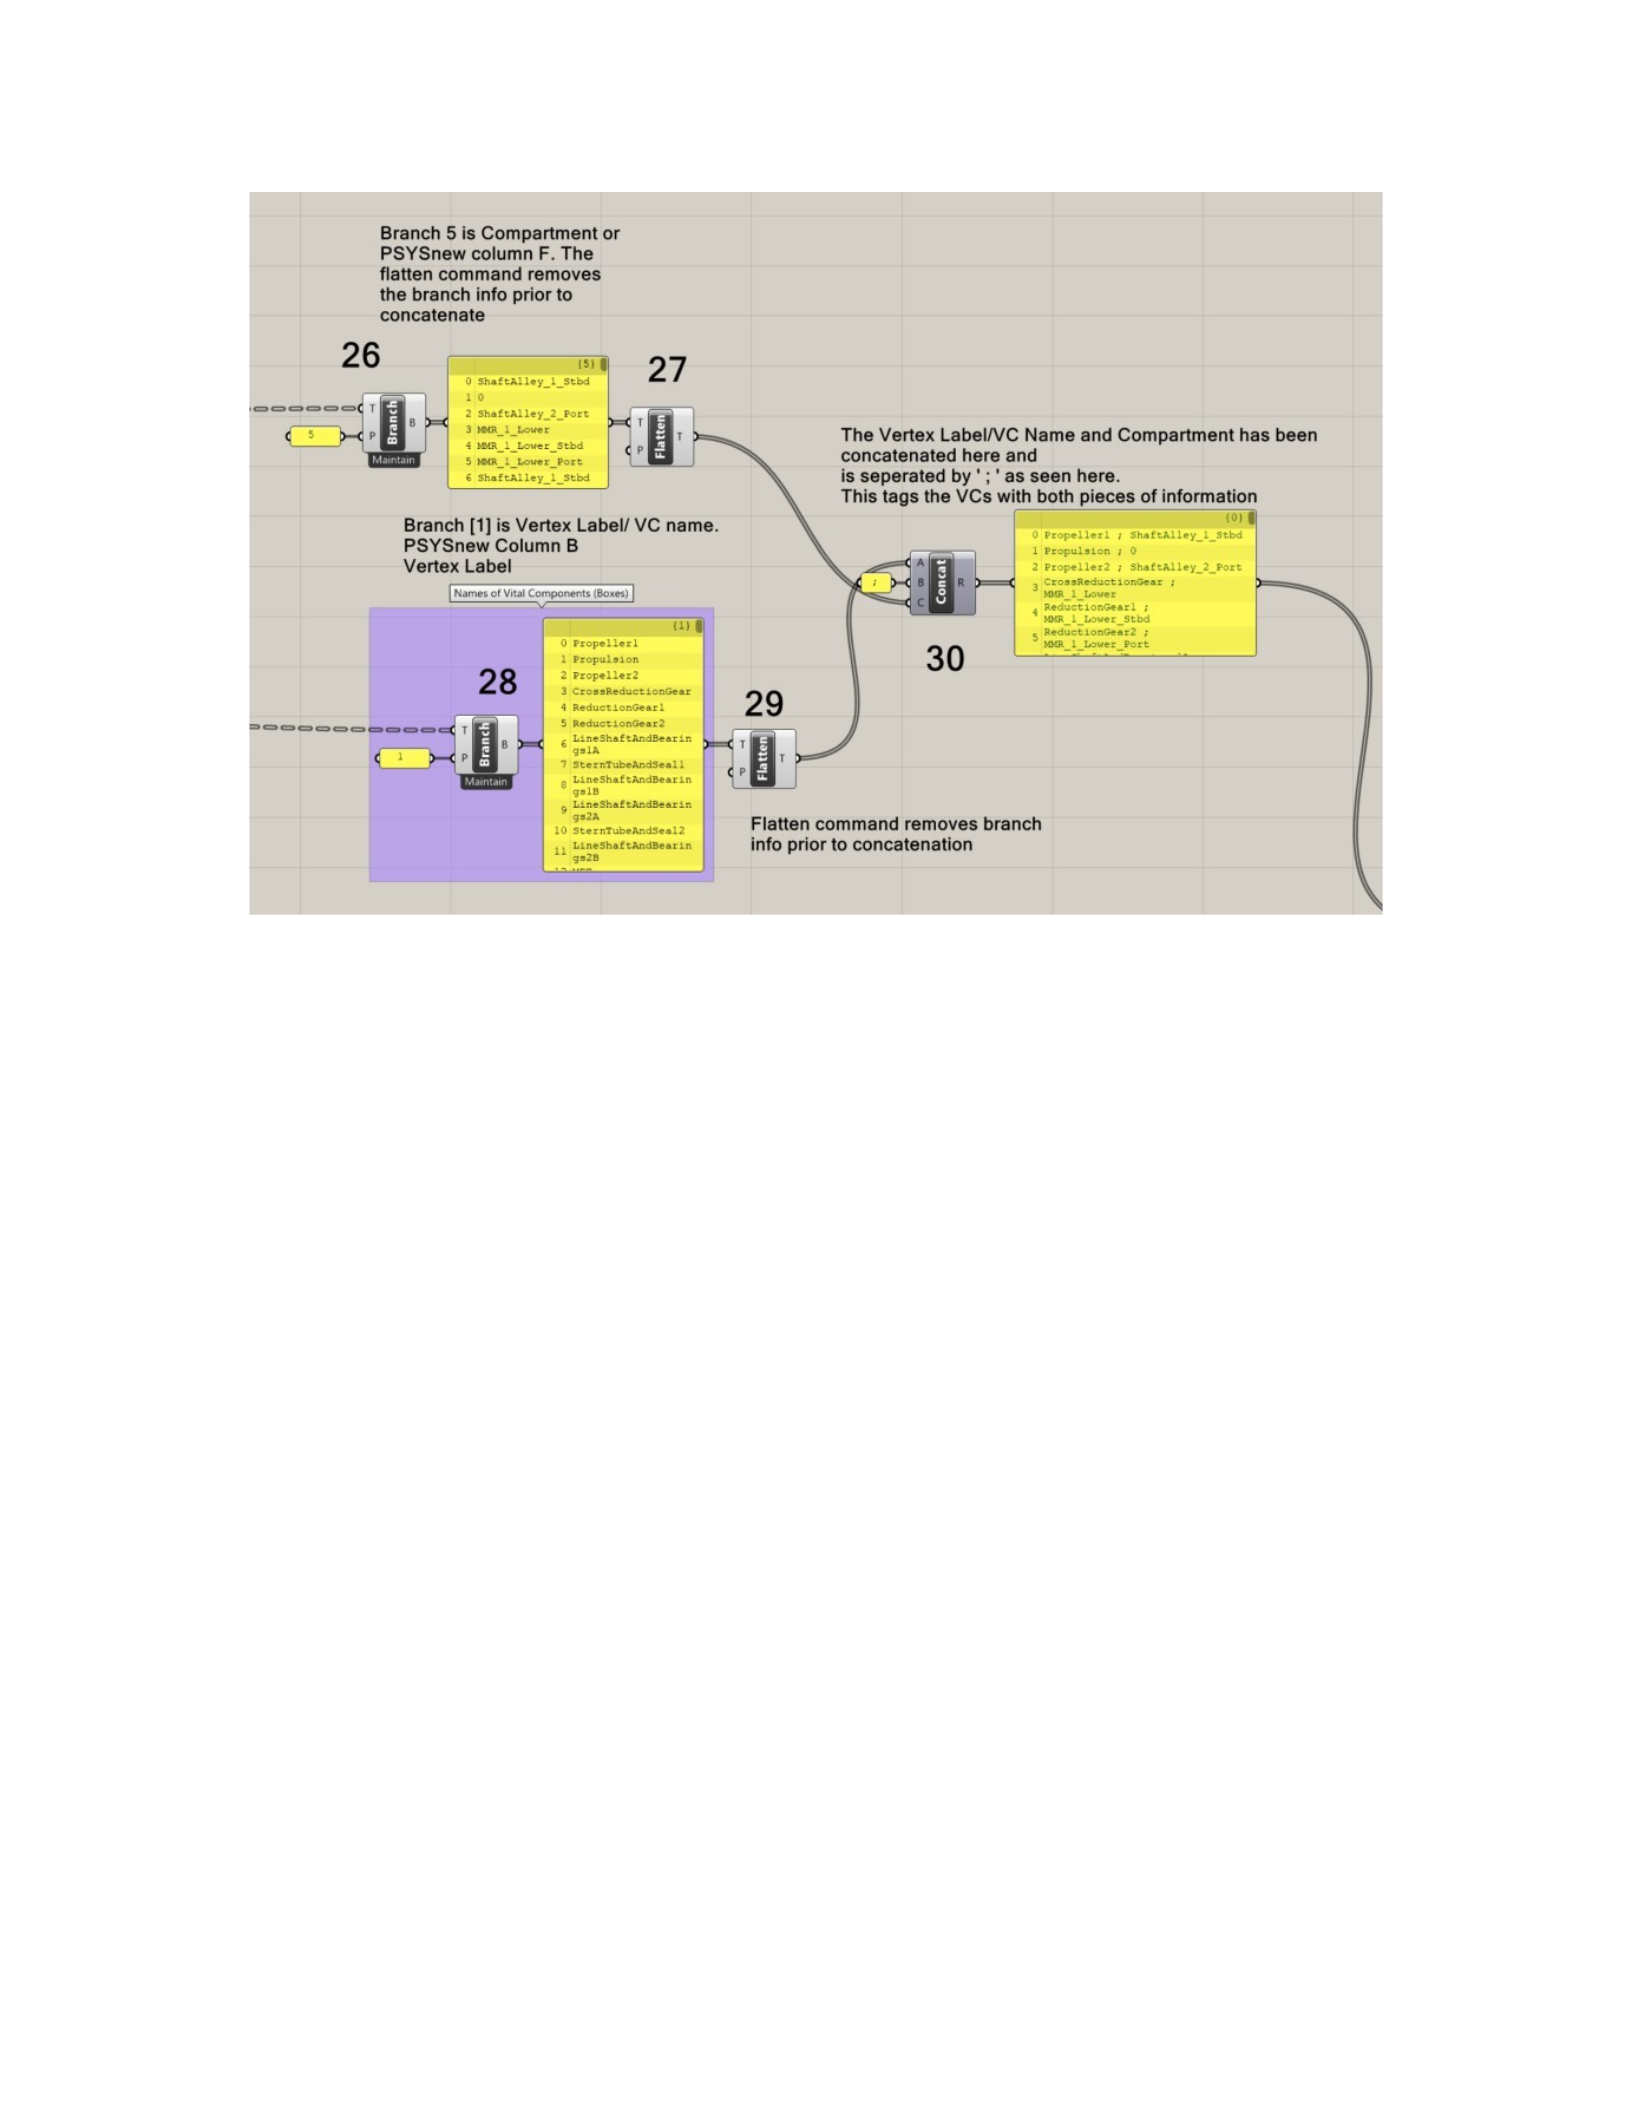
The Code of Locusts circled in black in figure A-9 will now be explained.
55
Figure A-12: VC Vertex Name and Compartment combined
Similar to the other parts of the Locust Code described earlier, blocks 26
and
28 shown above are branch information extracted from a larger data tree retrieved
from
SSM. Block 26 holds branch 5 which is the Compartment. Block 28 has branch
1, which is the name of the node. The panels to the right of block 26 and block 28
show this. In order for the node and compartment names to be combined into
a
single list, the "Flatten" Locust Command (blocks 27 and 29) is used to remove branch
information from the output of Blocks 26 and 28. It organizes the data for the "combine"
command shown in block 30. A semicolon is used to separate the values
from the two
lists, and the panel on the right shows the results of the Concatenate command.
The end result is that a list of 399 node names and compartments correlated with
399 VCs is now present in the worksheet and is ready to be placed as input for
the names of Rhinoceros Objects.
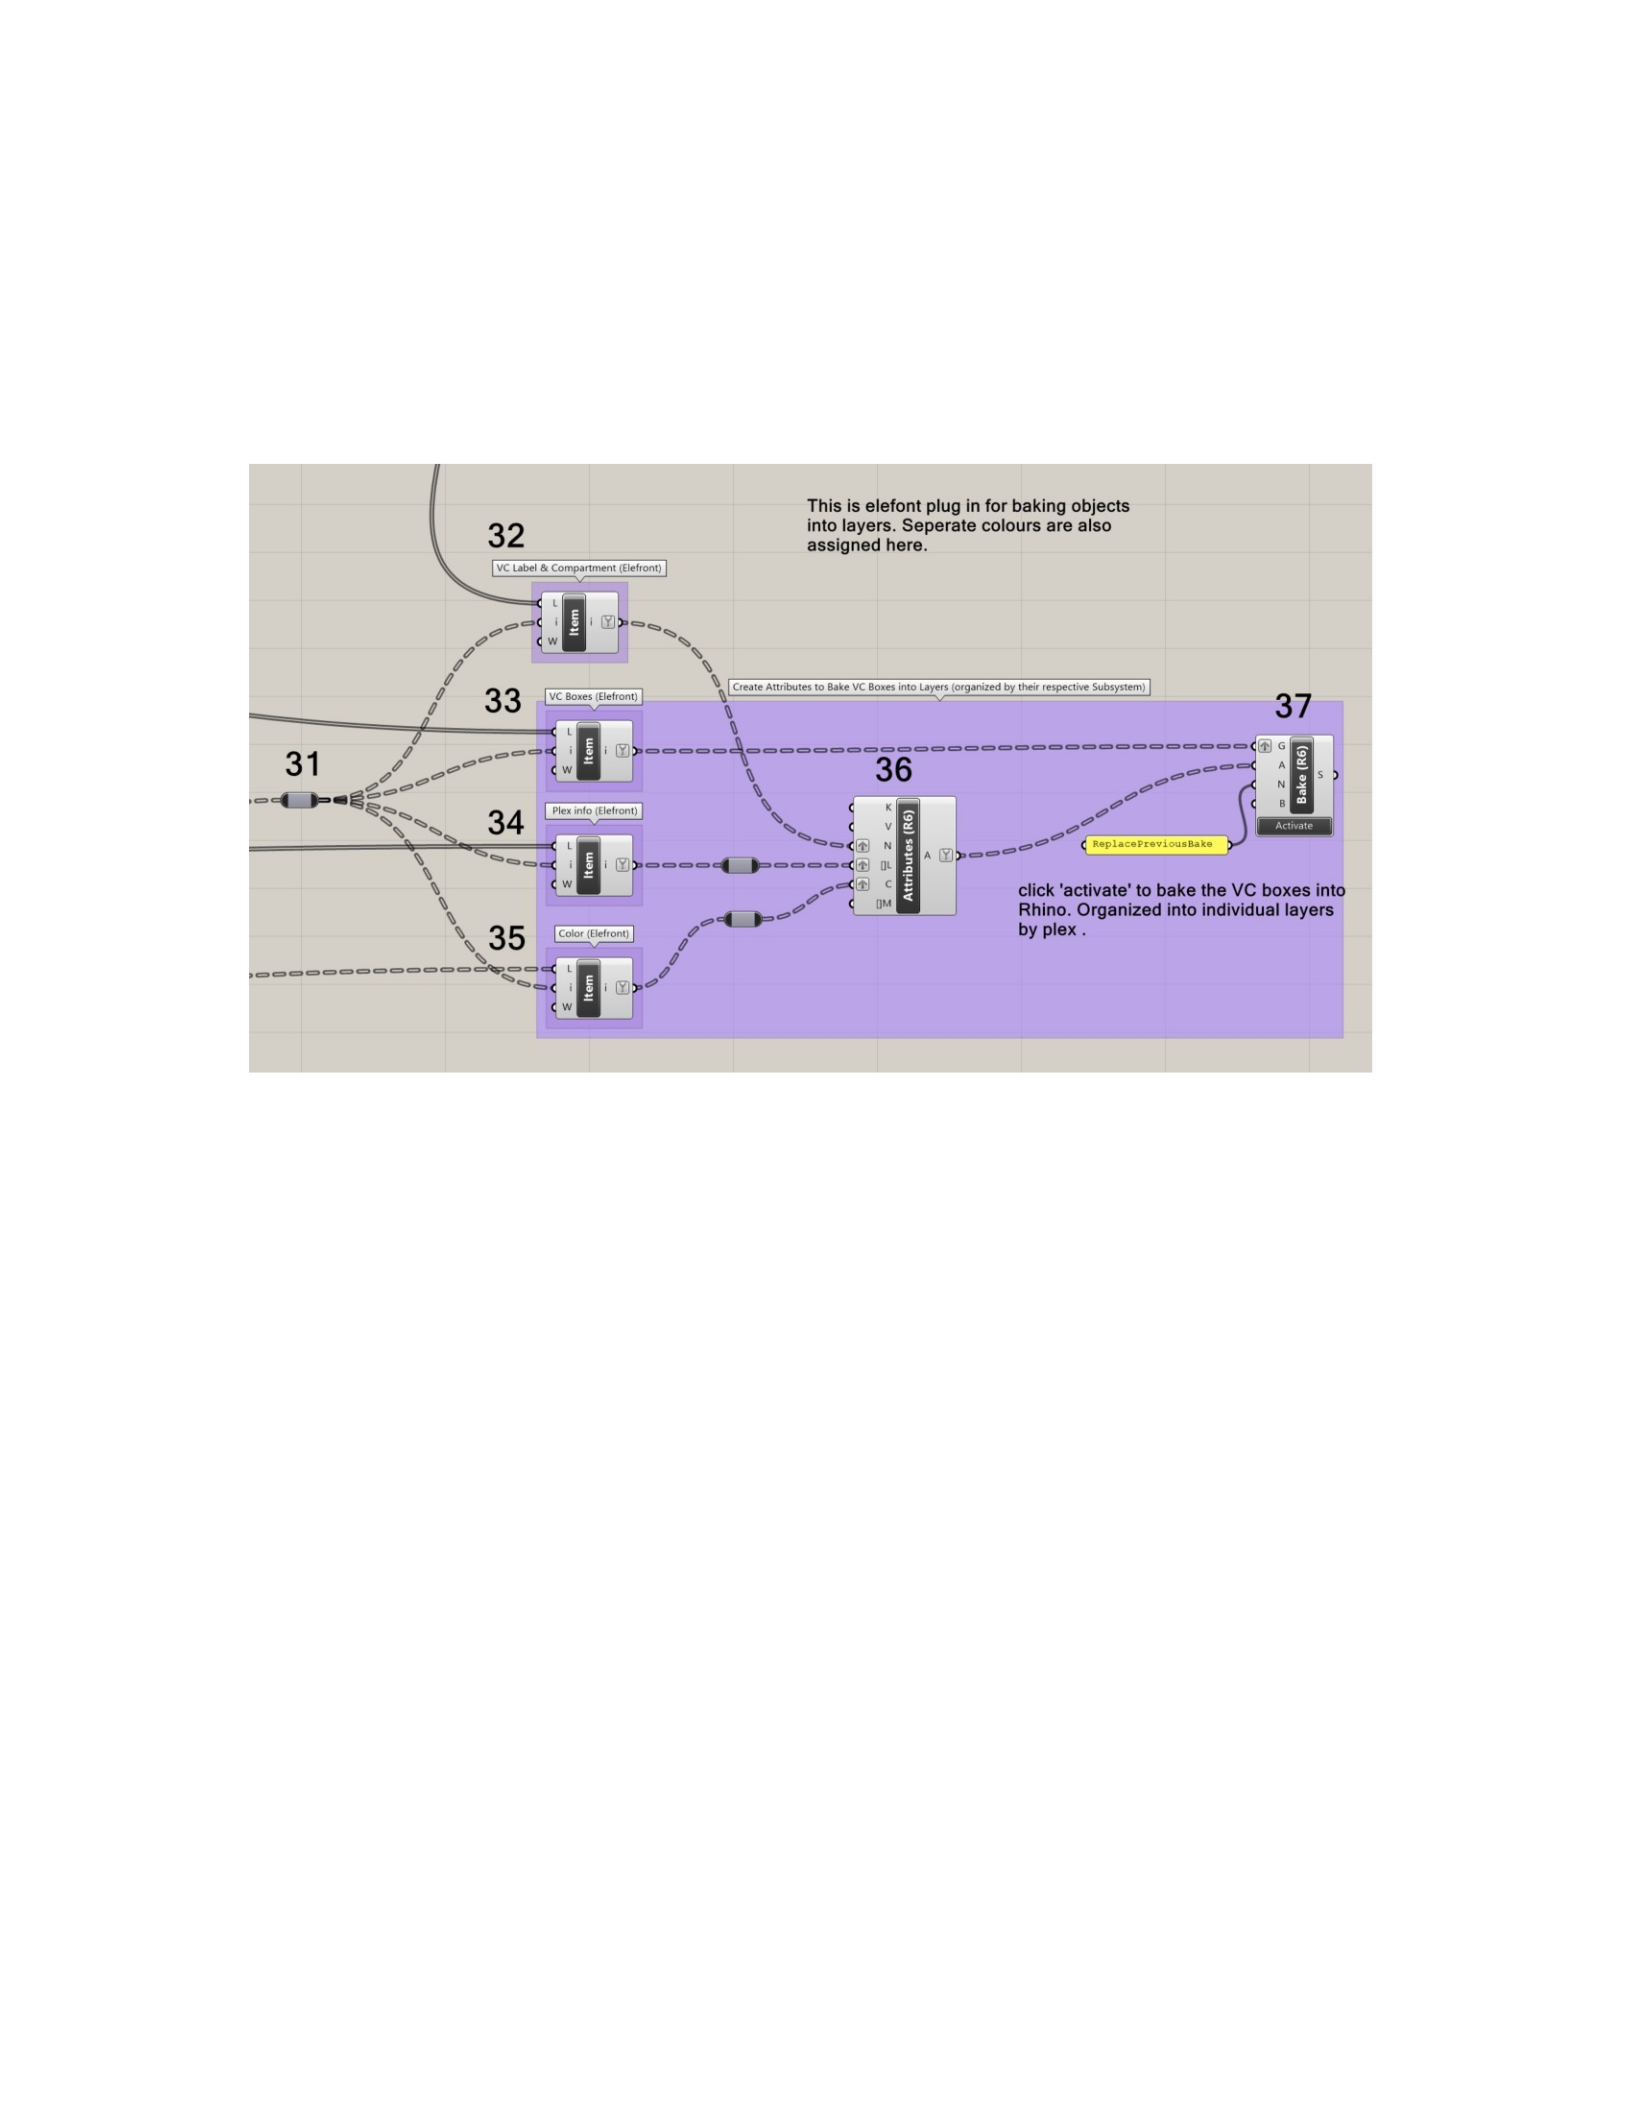
A.2.1 Bake VC Boxes with Attributes into Rhino
The Locust code circled in orange in image A-9 is the last part of the Grasshop-per
code that executes the ultimate goal of "baking" the Rhino object into the Rhino View-
port.
Figure A-13: VC Box Assigned Final Attributes and Baked into Rhino
All of the Grasshopper code blocks in this section come from the Elefront plug-
in. The most important block in this section is block 36 which is an attribute of
Rhino. With a focus on Block 36, the inputs N (Name), L (Layers), and C (Colour)
can be seen. Blocks 32, 33, and 35 provide information for these inputs. These three
blocks are connected by the section of code described earlier. Block 32 provides the
name of the object, Bock 34 provides layer information, and block 35 provides color.
The wire relay indicated by block 31 is connected to Block 22 which is a Sort Value
command. This function provides the number of objects categorized under each plex
and it ensures that the input data is set correctly before going into block 36.
Block 36 is connected to input A (attribute) of Block 37. As shown Block 33
provides Brep (VC Boxes) to input G (Geometry) to block 37. Now, all the necessary
information is there, and the user can select the "Activate" button located at the
bottom of block 37. All Rhino objects are now baked into the Rhino layer.

