


1
DESIGN AND VALIDATION OF BLADES FOR A HYDROKINETIC TURBINE TO
HARNESS WATER CURRENT ENERGY
Chapter 1: Introduction
Hydrokinetic energy extraction has become one of the main focuses in the search for sustainable
renewable energy sources, especially with the increasing global need for clean energy. Among
the different types of hydrokinetic energy, ocean currents stand out for their sustainability, high
power density, and relatively minimal environmental impact. Ocean currents offer great potential
to generate electricity reliably, with consistently predictable flow behavior.
The development of ocean current turbine (OCT) technology has prompted cross-disciplinary
research combining naval architecture, mechanical engineering, and fluid dynamics. This
approach includes numerical simulations based on the momentum theory of modified blade
elements, such as Prandtl's theory, to optimize the OCT design. One of the latest designs is a
three-blade single rotor consisting of 25 hydrofoils of varying thickness from root to tip,
designed to maximize hydrodynamic efficiency while reducing cavitation and drag effects.
The National Center for Southeast Marine Renewable Energy (SNMREC) plays a crucial role in
advancing OCT technology, with its preliminary research being the basis for the development of
cutting-edge designs. Numerical simulations and experimental investigations are carried out
iteratively to refine the OCT design, validate theoretical predictions, and ensure its performance
under real-world conditions. Previous research from Wenlong Tian et al. and Michael Borghi et
al. has shown the optimal performance of OCT rotors, with a maximum rotor power coefficient
of 0.45 and an average shaft power production of about 7.153 kW at 40 RPM.
The history of OCT's development can be traced back to the mid-20th century, inspired by the
principles of wind turbines adapted to meet the challenges of the underwater environment.
Pioneering work in aerodynamic theory, such as the theory of blade element momentum, became
the basis for the design of OCT hydrodynamics, demonstrating the multidisciplinary nature of
this field.
The combination of numerical simulation and experimental validation forms the cornerstone of a
comprehensive approach to optimizing OCT designs. SNMREC, through global collaboration
and innovative approaches, continues to push the boundaries of renewable energy technologies,
reflecting a commitment to sustainable practices and reduced reliance on fossil fuels.
On the experimental front, the physical prototype undergoes careful testing to validate numerical
predictions and assess real-world performance. Theoretical modeling analogies and practical
experiments ensure a holistic understanding of capabilities, limitations, and potential areas for
OCT improvement. The multidimensional investigation, which includes both numerical and
experimental perspectives, ensures a robust and thorough evaluation of OCT designs, paving the
way for progress in sustainable energy solutions.
In 2016 the World's Total Primary Energy Supply (TPES) by fuel was Oil, 31.9%; coal, 27.1%;

2
Natural gas, 22.1%; Biofuels and Waste, 9.8%; Nuclear, 4.9%; Hydro, 2.5%; and others that can
be updated resources 1.7%. It is clear that TPES with clean renewable energy is very small and
needs to be developed (69). Bobby Zarubin noted that the best sites to harness ocean current
energy are between islands where tidal currents are strongest or locations in the ocean where the
temperature difference is around 20°C between warm surface water and cold deep water.
Global energy consumption is expected to increase, mainly supplied by the growth of renewable
energy resources, for example, solar, wind, water, and sea. Energy production from natural
resources is expected to generate about half or more of electricity demand in Europe and North
America by 2050, contributing to renewable policy goals. Expanding renewable energy
generation is a key component, and its performance has a substantial effect on the efficiency of
the system. Hydrokinetic renewable energy, which refers to the energy obtained from the
movement of water, offers many advantages compared to traditional forms of energy production.
One of the main advantages of energy that does not produce harmful emissions or waste
products. Unlike fossil fuels, which contribute to global climate change, hydrokinetic energy
does not produce greenhouse gases, making it a sustainable and environmentally friendly energy
source. One of the advantages of hydrokinetic energy is that it is very unsurprising, making it
easier to coordinate into the network and to anticipate future energy needs. Ocean flows, for
example, are predictable and reliable, providing a consistent and stable source of energy that can
be used to supply homes and organizations. Hydrokinetic energy is also highly effective, with the
capacity to generate power at a much higher rate than other types of environmentally friendly
power, such as breeze or sunlight-based power. This implies that hydrokinetic energy may be
able to meet most of the world's energy needs, especially in coastal areas where ocean currents
are most embedded. In addition, hydrokinetic energy has quite less ecological effects compared
to various types of energy creation such as hydroelectric dams. Underwater hydrokinetic turbines
do not require the development of large-scale foundation projects that can disrupt biological
systems and regions, making them more practical and harmless to ecosystems. In general, the
benefits of environmentally friendly hydrokinetic power make it a promising and alluring option
for meeting the world's economically growing energy needs and not harmful to ecosystems. (70)
In some parts of this study, we proposed a precise numerical simulation model to design a small-
scale three-blade horizontal underwater current turbine tested in a laboratory towing tank located
at the University of New Orleans. The purpose of this study is to improve the performance of the
OCT and to achieve maximum power and optimal net torque for approaching flow currents. In
such a way, our examination of small-scale OCT is critical in developing new advances and
working on the efficiency of existing frameworks. A detailed examination of the three-blade
rotor OCT is presented to find the ideal rpm (revolutions per minute) in accordance with the
natural conditions in order to collect the maximum possible energy from the OCT in the flow of
the towing tank. Our methodology is to utilize the Blade Element Momentum (BEM) hypothesis
to assess the hydrodynamic characteristics for the rotor. This approach has been used by
VanZwieten and his group in other studies, for example, one for the optimization of a three-blade
design for horizontal axis underwater currents (VanZwieten et al., 2016) (71) and another on the
impact of turbulence on the performance of vertical axis turbines (VanZwieten et al., 2019) (72).
They have also analyzed the influence of different blade designs on OCT performance
(VanZwieten et al., 2018) (73) and the impact of blade shape on energy extraction in tidal turbine
arrays (VanZwieten et al., 2017) (74).

3
Research by Zhou et al. (2017) (75) used computational fluid dynamics (CFD) simulation to
improve OCT blade geometry. They found that a blade with a thickness to chord ratio of 8% and
a pitch angle of 15 degrees gave the most energetic results.
In line with that, another study by Bhuiya et al. (2018) (76) examined the impact of blade shape
on OCT performance and found that blades with tapered hydrofoil and elliptical shape produced
the highest power coefficient.
One more important part of the OCT configuration is the choice of materials. Research by
VanZwieten et al. (2015) (77) investigated the utilization of composite materials in OCT blade
design and found that composites manufactured using carbon fiber and epoxy resin offer the best
combination of solidarity, firmness, and weight.
In a comparable study, Cusson et al. (2016) (78) found that blades made of glass and
polyurethane composites are more resistant to fatigue and erosion than blades manufactured
using aluminum or steel.
OCT performance is also affected by its orientation in the water. A study by Yin et al. (2018)
(79) explored the impact of blade orientation on OCT performance and found that turbines with a
30-degree approach gave the most powerful results.
Another study by Stijepovic et al. (2016) (80) found that OCTs with blades located at an angle
of 45 degrees to the ongoing flow provided the highest power coefficient.
This dissertation critically examines the correlation between experimental results and numerical
models, specifically the Blade Element Momentum theory and the Ansys Fluent simulation.
Quantitative analysis highlights the strengths and limitations of each model, sheds light on
differences and provides insights for future refinements.
The success of numerical models in predicting propeller performance underscores the importance
of computational tools in the iterative design process. The dissertation discusses the nuances of
numerical simulation, discussing factors such as hydrodynamic forces, fluid structure
interactions, and turbulence effects considered in the model.
The findings of this dissertation have significant implications for the field of marine energy
extraction. The successful design, fabrication, and testing of carbon fiber propellers for 3-blade
horizontal axis OCT not only contributes to the understanding of turbine dynamics but also
offers a real solution to improve the efficiency of marine renewable energy systems.
The utilization of carbon fiber and 3D printing technology in propeller fabrication presents an
innovative, scalable approach for a wider range of applications in the renewable energy sector.
The alignment between experimental and numerical results improves the reliability of predictive
models, paving the way for more accurate judgments of future turbine designs.
In conclusion, this dissertation represents a holistic exploration of the design, fabrication, and
testing of carbon fiber propellers for 3-blade horizontal axis ocean current turbines. The
integration of SolidWorks software, carbon fiber materials, and 3D printing technology
demonstrates the interdisciplinary nature of the research, combining engineering, materials
science, and manufacturing expertise.
Experimental validation in the University of New Orleans' towing tank, with results reflecting
numerical predictions from the Blade Element Momentum theory and Ansys Fluent simulations,
confirmed the efficacy of the designed propeller. The dissertation contributes to

4
The ongoing discourse on ocean energy extraction, emphasizes the practical feasibility of the
proposed propeller design and its potential impact on the advancement of marine renewable
energy technology.
The dissertation unfolds as a comprehensive journey across five interconnected chapters, each
contributing as an important aspect to an overarching narrative of ocean current turbine (OCT)
technological advancements. Chapter 2 begins the expedition by immersing itself into the
intricate process of deriving models, emphasizing the importance of a methodical approach to
achieving a representative miniature prototype. This chapter also conducts a thorough analysis of
the hydrodynamic coefficients for each turbine blade cross-section. The goal is to illuminate the
nuanced interactions between the blades and dynamic ocean currents, an important step in
understanding the hydrodynamics that govern turbine performance. Transitioning seamlessly into
Chapter 3, the focal point shifts to the heart of the OCT – the propeller. This section not only
details the intricacies of the design but also explores the important decisions surrounding
material selection, highlighting the innovative use of carbon fiber. The results of 3D printing, a
testament to modern manufacturing techniques, are revealed to be an important element in the
narrative, connecting theoretical designs with real-world prototypes and providing insight into
the propeller's manufacturability and structural considerations.
Chapter 4 enhances the discussion by investigating the theoretical underpinnings of the Blade
Element Momentum (BEM) theory. Serving as the theoretical backbone of the dissertation, this
chapter describes the principles that guide propeller performance prediction. It offers valuable
insights into the complex fluid dynamics and hydrodynamics that play a role in the interaction
between turbine blades and ocean currents. The intricate interaction between design
considerations, hydrodynamic coefficients, and BEM theory forms the basic structure on which
the following chapters are built. Chapter 5 takes exploration a step further, immersing itself into
the realm of Computational Fluid Dynamics (CFD) simulation using Ansys Fluent. This chapter
acts as a bridge between theory and application, utilizing advanced numerical simulations to
predict propeller behavior under various conditions. The integration of CFD simulations in this
dissertation not only validates the theoretical framework but also sets the stage for a deeper
understanding of propeller performance in diverse ocean scenarios. This chapter provides
comprehensive insights into fluid flow patterns, pressure distribution, and other important
parameters that affect the efficiency and performance of the propeller.
Together, these chapters build a comprehensive narrative that cuts across the intricacies of
scaled-down modeling, hydrodynamic coefficient analysis, propeller design and fabrication,
theoretical foundations in BEM theory, and advanced CFD simulations. The dissertation, thus,
summarizes a holistic exploration of ocean current turbine technology, embracing theoretical
rigor, practical applications, and innovative manufacturing techniques. The seamless progression
from a miniature model to a real-world propeller, coupled with a theoretical foundation firmly
rooted in BEM theory and validated through CFD simulations, positions this dissertation as a
significant contribution to the growing field of marine renewable energy. The interconnectedness
of these chapters serves as evidence of the multidisciplinary approach used, bringing together
principles from fluid dynamics, materials science, and engineering to create a cohesive and
impactful body of research. This dissertation not only seeks to advance the understanding of
ocean current turbine technology, but also offers a blueprint for future research efforts, inspiring
innovation and sustainable exploration in the field of sustainable energy solutions.

5
As the world continues to look for sustainable alternatives, the findings presented here contribute
valuable insights and methodologies to future research in the emerging field of ocean current
turbines. The successful integration of theoretical design, advanced fabrication techniques, and
rigorous experimental validation positions this work as a significant step towards harnessing the
enormous energy potential inherent in ocean currents.

6
Chapter 2: Downscale the model and Analyze the Hydrodynamic Coefficient
The careful study of hydrofoil design stands as an indispensable cornerstone in the field of
hydrodynamic engineering, having profound implications for the lift and drag characteristics of
propellers and turbines. In this investigative effort, our focus was honing on 25 specific airfoil
coordinate files, each carefully labeled according to systematic naming conventions. These
airfoils, representing a wide range of hydrofoil designs, are a fundamental element in
understanding the intricate interactions between form and function in rotor aircraft. Integral of
this inspection are two important parameters – rotor diameter and rotation speed – that exert a
real influence on the overall performance of the propeller or turbine system. The acquisition of a
hydrofoil coordinate file is an important step, each file houses a series of data points that
meticulously define the contours and dimensions of the hydrofoil. This wealth of data is key to
further analysis, leveraging advanced computing tools tailored for nuanced airfoil data
processing.
The comprehensive investigation goes beyond just hydrofoil data acquisition to detailed scrutiny
of the intricacies inherent in each design. The computational tools used in this study serve as an
invaluable means of unraveling the mysteries of hydrodynamic performance, facilitating a
careful examination of lift and drag characteristics. The visualization of the shape of this
hydrofoil becomes important in the quest for understanding, making it possible to distinguish
variations in thickness and geometry along radial elements. This analytical approach goes
beyond mere quantitative assessments, investigating the qualitative realm of design intricacies
that hold the key to optimizing the performance of rotor aircraft.
In the broader context of this hydrodynamic investigation, a noteworthy highlight is the
consideration of full-scale propellers tested and used by the Southeast National Marine
Renewable Energy Center (SNMREC) at Florida Atlantic University. This engineering marvel
encapsulates the synthesis of cutting-edge design principles and practical applications,
exemplifying the pinnacle of effectiveness and performance in marine renewable energy
systems. Propellers, evidence of the collaborative efforts of researchers and engineers, show a
confluence of attributes that increase their efficacy. The design, informed by insights gathered
from the analysis of the shape of the hydrofoil, displays a harmonious balance between lift, drag
and structural integrity. Rotor diameter and rotation speed, identified as important parameters in
hydrodynamic investigations, are carefully calibrated in full-scale propellers to maximize
efficiency in real-world conditions.
In addition, the performance of the propeller is closely related to the shape of the hydrofoil used,
with systematic analysis revealing nuanced variations important for optimizing energy extraction
from ocean currents. The interaction between design parameters, computational analysis, and
real-world testing underscores the depth of engineering ingenuity contained in these propellers.
Its application by SNMREC at Florida Atlantic University is not just a technological
achievement; This is an important step forward in the practical application of hydrodynamic
principles to sustainable energy solutions.
In essence, this paragraph summarizes the journey from the systematic study of hydrofoil design
to the real-world application of these insights in full-scale propellers. It underscores the
interconnectedness of theoretical analysis and practical engineering, demonstrating how a careful
understanding of the shape of the hydrofoil and design parameters can lead to the creation of
highly effective and performance-optimized marine renewable energy systems. Paragraphs are
not only

7
outlining the technical intricacies of hydrodynamic investigations but also emphasizing real-
world impact through the magic of full-scale propeller engineering, highlighting its role as a
beacon of innovation in the pursuit of sustainable energy solutions.
Exploration of geometric properties and performance predictions for life-size rotor blades is an
integral aspect of the study, with the primary focus on optimizing power generation from the
resilient Florida Current. Tailored for applications on the Southeastern National Marine Energy
Center's (SNMREC) experimental 20 kW ocean current turbines, these stall-regulated rotors
operate at a specified 50 RPM. The basic goal was to create a rotor blade capable of utilizing the
maximum amount of power, in harmony with the characteristics of the Florida Current. At the
rotational speed of the design, the stall-regulated rotor blades are engineered to produce
approximately 20 kW of shaft power. The tri-blade configuration, operating at a fixed RPM of
50, takes inspiration from the comparative analysis detailed in the reference
(70). The selection of airfoils for this optimization process relies on the type of FX_77_W,
informed by the insights presented in (2). To navigate these optimization intricacies, the
powerful HARPOpt tool (72) takes center stage. In pursuit of near-optimal design, the
optimization settings outlined in (71) were adopted, albeit with strategic adjustments – the
number of individuals counted in each iteration increased from 100 to 150. This augmentation
aims to increase the chances of unearthing a design that aligns with Florida Current's unique
demands. It is noteworthy that (71) underlines a certain degree of variability in performance
prediction and geometry across optimization executions, indicating a standard deviation of 14.8
W in the case with 100 individuals. To reduce this variability, five optimization experiments
were conducted, each employing 150 people in an attempt to increase the probability of finding a
design that was close to optimal.
The experimental landscape unfolds as each optimization execution assesses five different
airfoils – FX77W121, FX77W153, FX77W258, FX77W270, and FX77W243 – following the
optimization inputs detailed in [2]. The aim was to examine its performance under consistent
optimization settings, discerning the nuanced impact of airfoil selection on the overall
effectiveness of the rotor blades. A careful examination of the results reveals that although the
predicted performance and geometry may show slight variation between optimization
executions, the overarching goal remains steadfast: to identify the configuration that results in
the highest average power production. From the quintset of optimization experiments, an
interesting result emerged – the run with the highest average power production reached an
impressive 7,405 kW. However, it is crucial to acknowledge the variability inherent in the
optimization process, as reflected in the standard deviation of the average shaft power calculated
for each optimization execution, standing in the
This slight variation underscores the sensitivity of the optimization results to the selected
parameters and the complex interaction of factors affecting the performance of the rotor blades.
The range observed in average shaft power further accentuates the intricacies at play, fluctuating
between the aforementioned 7.367 kW and 7.405 kW. These variances, while demonstrating the
variability inherent in the optimization process, also provide valuable insight into the robustness
and stability of the rotor blades designed across multiple iterations. Collectively optimization
experiments contribute to a nuanced understanding of the intricate relationship between airfoil
selection, geometric properties, and the power production generated. The iterative approach,
which includes multiple experiments with parameter variations, serves as strategic
8
methodology for navigating the complexity of rotor blade design for ocean current turbines. This
paragraph summarizes the meticulous optimization journey, illuminating not only the technical
intricacies of the process but also the strategic adjustments made to increase the likelihood of
uncovering an optimal design tailored to the dynamic conditions of the Florida Current.
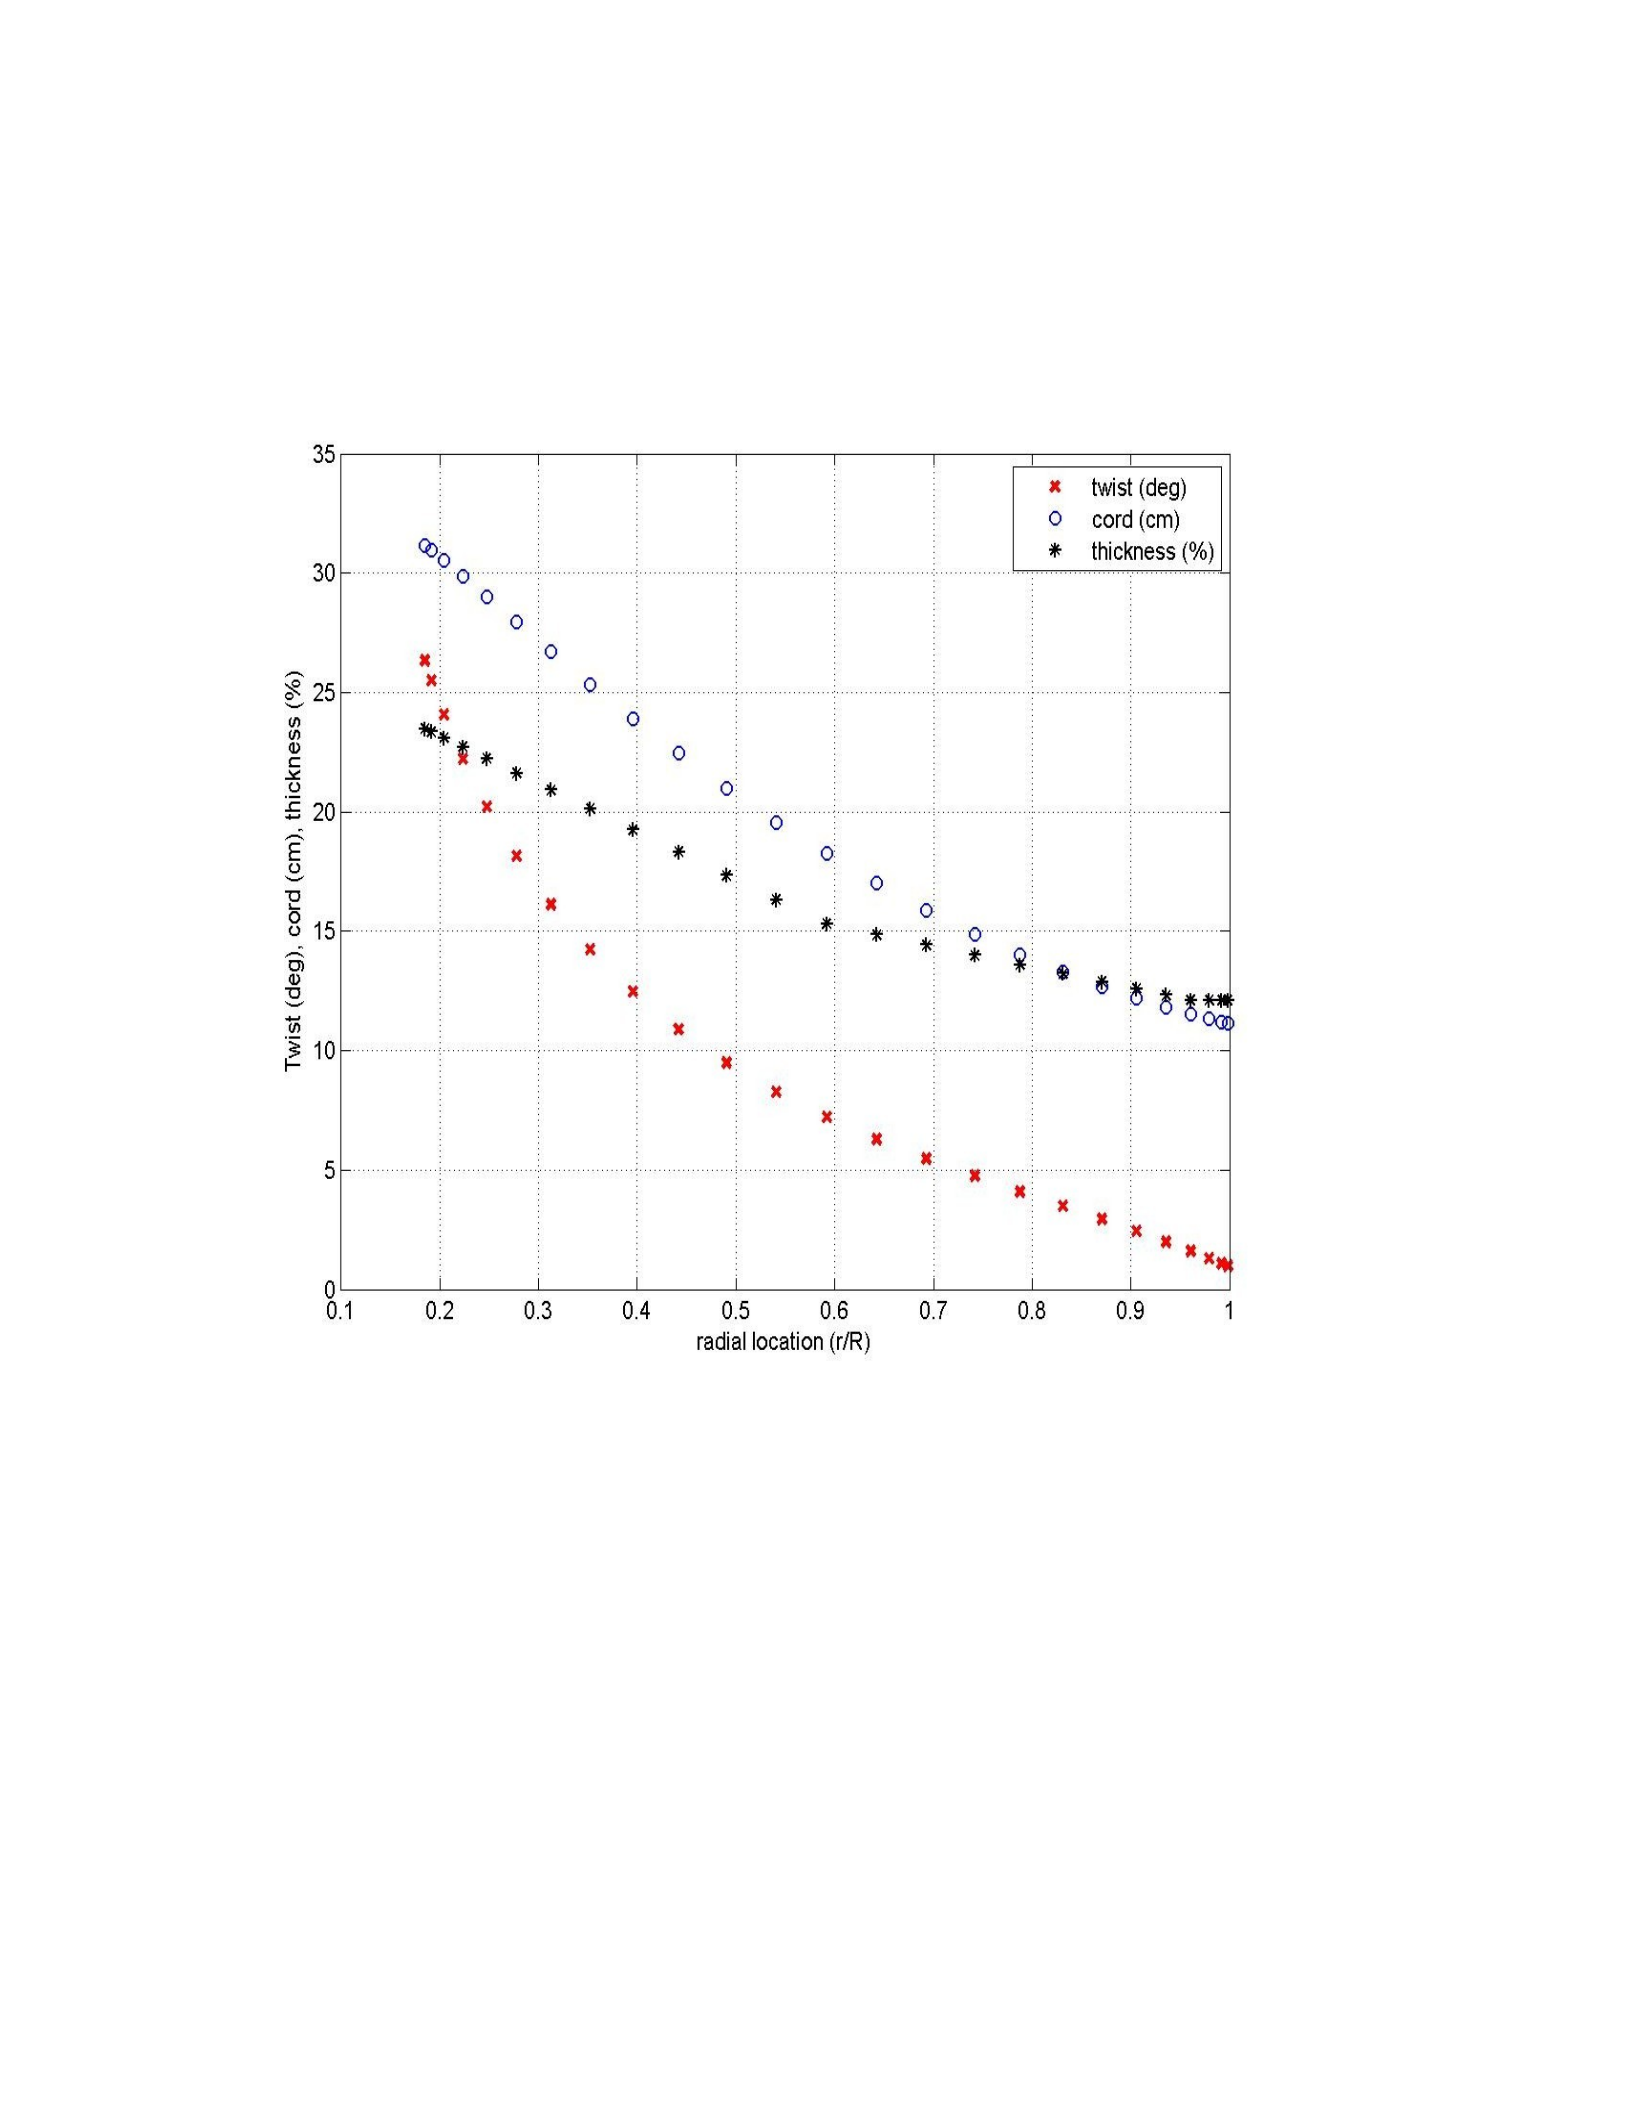
Figure 2.1. The rotor geometry for the rotor is optimized to operate in the Florida Current at
a fixed operating speed of 50 RPM.
The hydrofoil incorporated into the propeller design is the FX-77-W type, a typical airfoil
known for its outstanding properties. In this family of airfoils, a systematic naming convention
is used, in which the last three digits in the nomenclature roughly correspond to the ratio of
thickness multiplied by 1000. This nomenclature gives engineers

9
A convenient reference to the thickness of the airfoil, facilitating a direct understanding of its
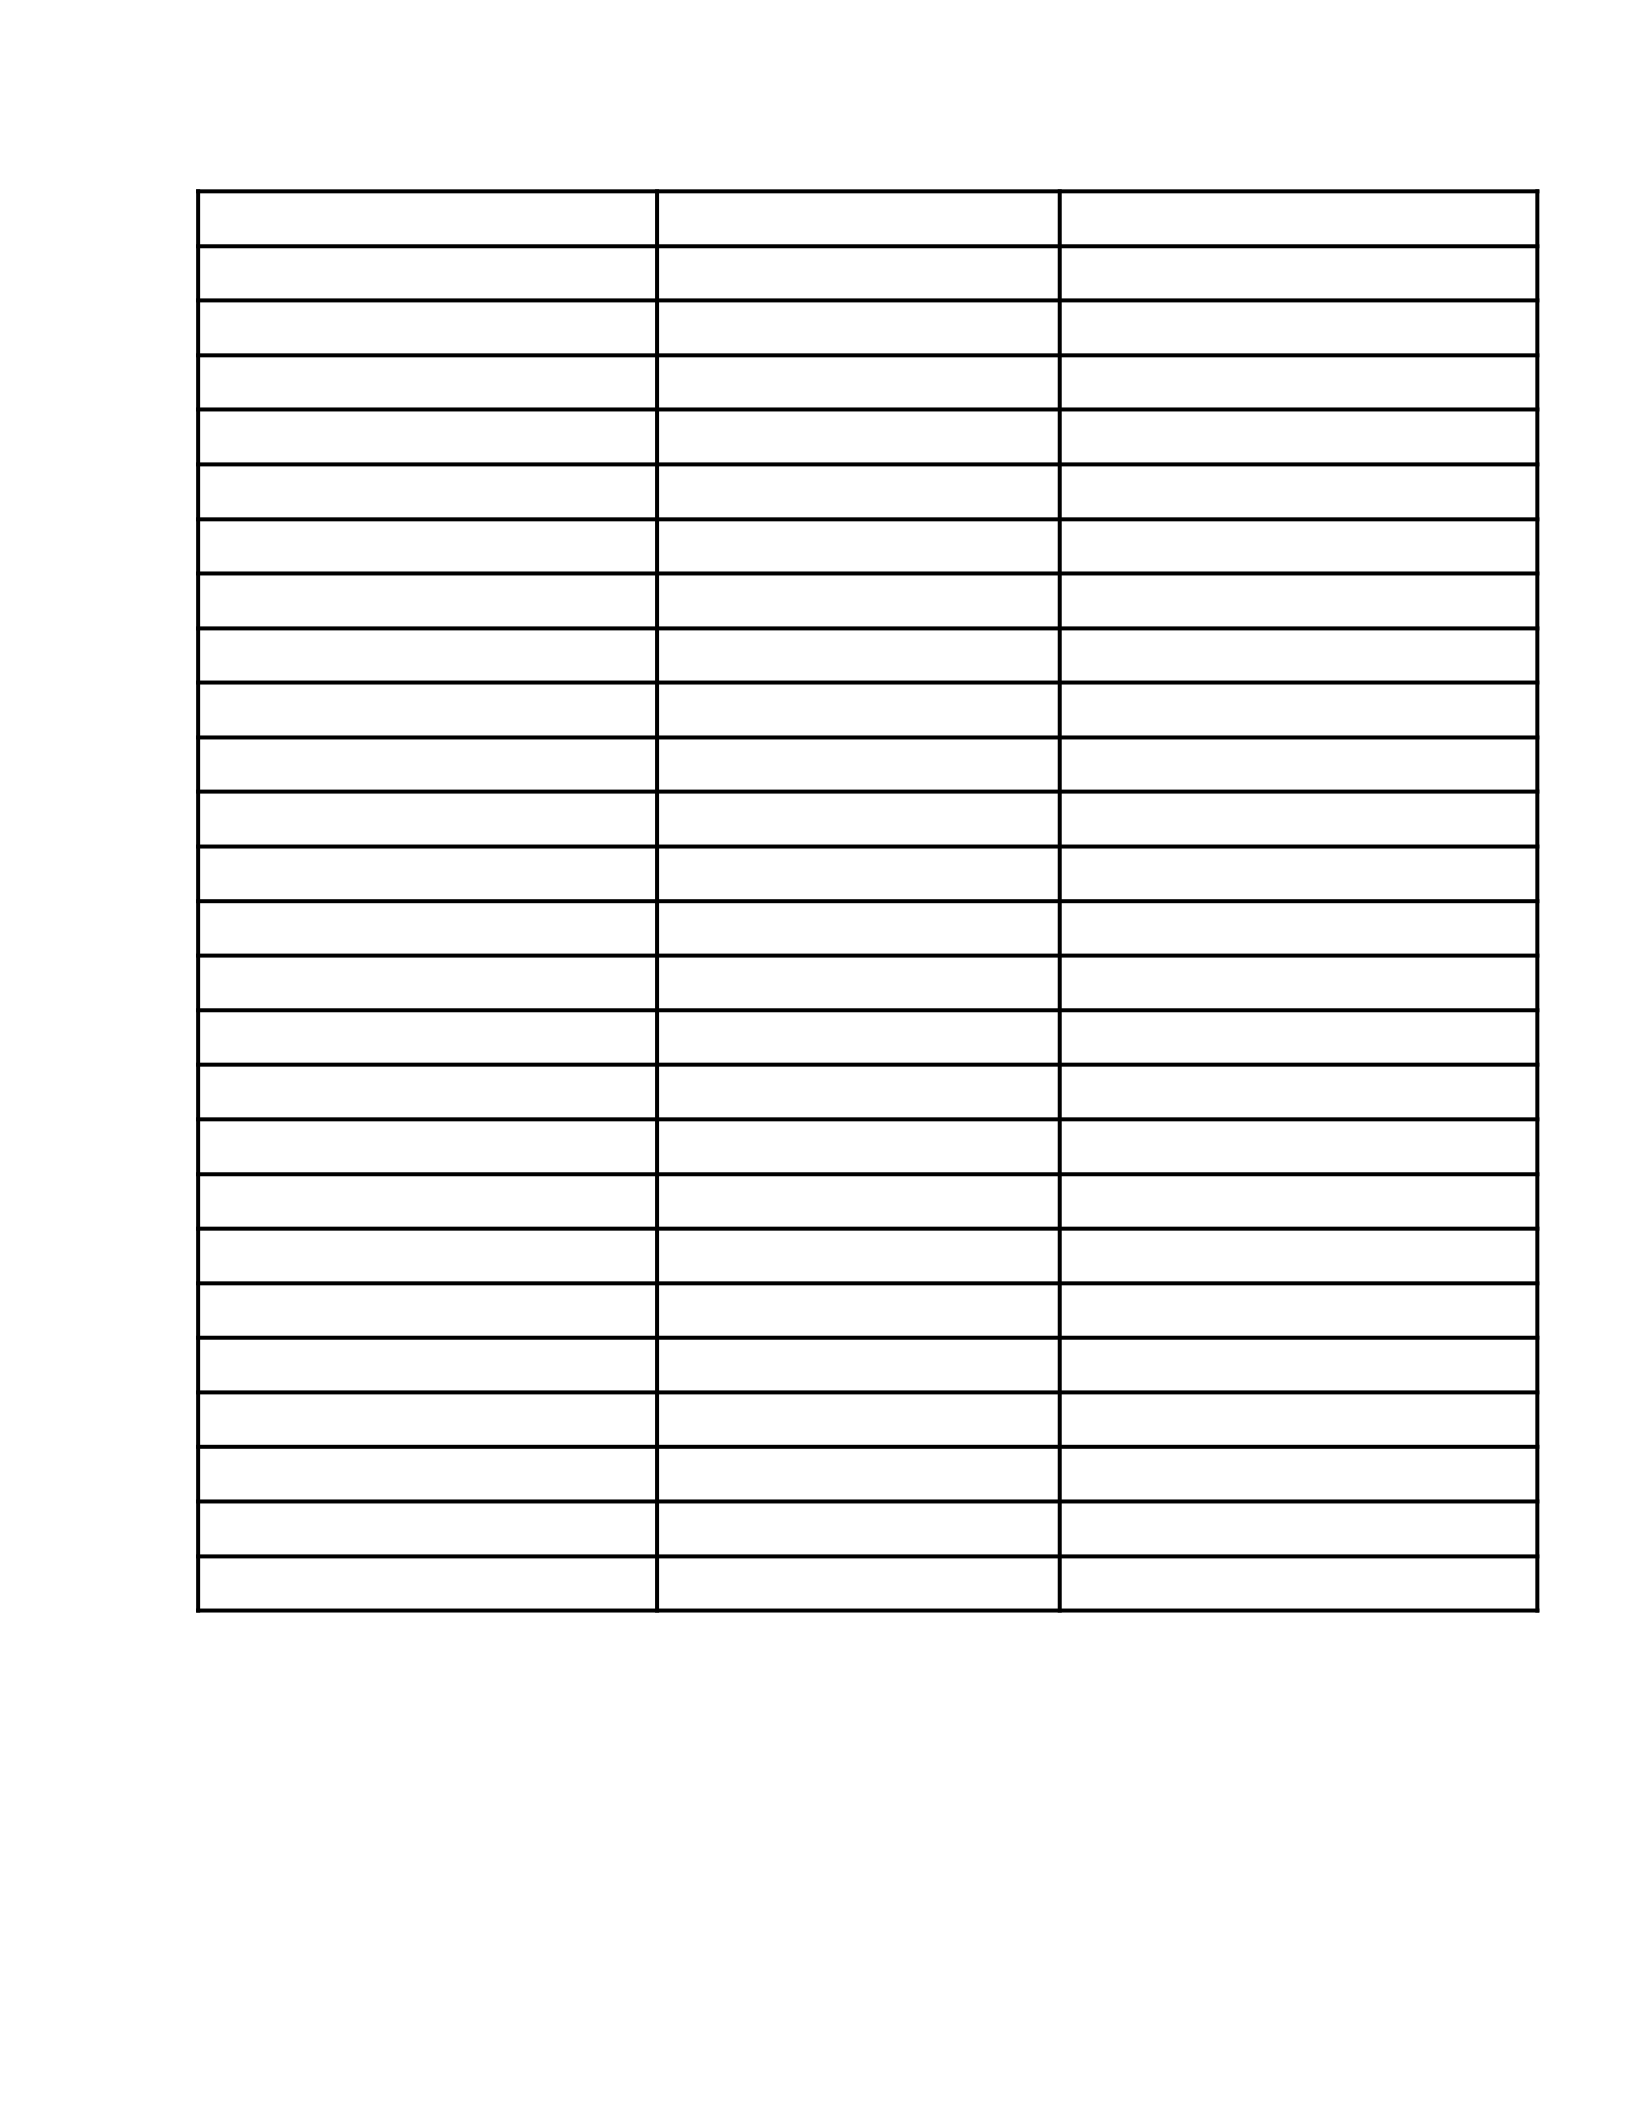
geometric properties. For example, an airfoil denoted as FX77153 has a thickness ratio of 15.3%.
Utilizing this naming convention, engineers can seamlessly interpolate between the original
FX77W121 shape and its counterparts, i.e., FX77W153 and FX77W258 shapes, to produce a
spectrum of geometric shapes for airfoils. As a result, the propeller airfoil shows a range of
thickness percentages, ranging from 12.1% to 23.49%. This thickness ratio variability offers a
spectrum of design possibilities, allowing for tailored adjustments to optimize propeller
performance under diverse operational conditions. The correlation between the name of the
hydrofoil and its thickness percentage is each captured succinctly in Table 2.1, providing a
comprehensive reference for the design team as they navigate the intricacies of propeller
geometry and aerodynamics. This paragraph not only describes the utilization of certain types of
airfoils that are known for their beneficial properties but also underlines the deliberate and
systematic approach taken in selecting and manipulating the shape of the airfoil to create
propellers that are tailored for optimal performance in various scenarios.
10
Hydrofoil number Hydrofoil name Percent Thickness
1FX77_02349_01 23.49%
2FX77_02336_02 23.36%
3FX77_02301_03 23.01%
4FX77_02273_04 22.73%
5FX77_02223_05 22.23%
6FX77_02162_06 21.62%
7FX77_02092_07 20.92%
8FX77_02012_08 20.12%
9FX77_01925_09 19.25%
10 FX77_01832_10 18.32%
11 FX77_01734_11 17.34%
12 FX77_01633_12 16.33%
13 FX77_01530_13 15.30%
14 FX77_01486_14 14.86%
15 FX77_01442_15 14.42%
16 FX77_01400_16 14%
17 FX77_01360_17 13.60%
18 FX77_01323_18 13.23%
19 FX77_01289_19 12.89%
20 FX77_01258_20 12.58%
21 FX77_01225_21 12.25%
22 FX77_01194_22 11.94%
23 FX77_01164_23 11.64%
24 FX77_01134_24 11.34%
25 FX77_01107_25 11.07%
Table 2.1 (Hydrofoil Information)
11
Rotor Diameter 20 m
Hub Diameter 3 m
Pre-cone corners 0°
Swivel Angle 0-40°
Number of Knives 3
Speed of operation approach Variable speed
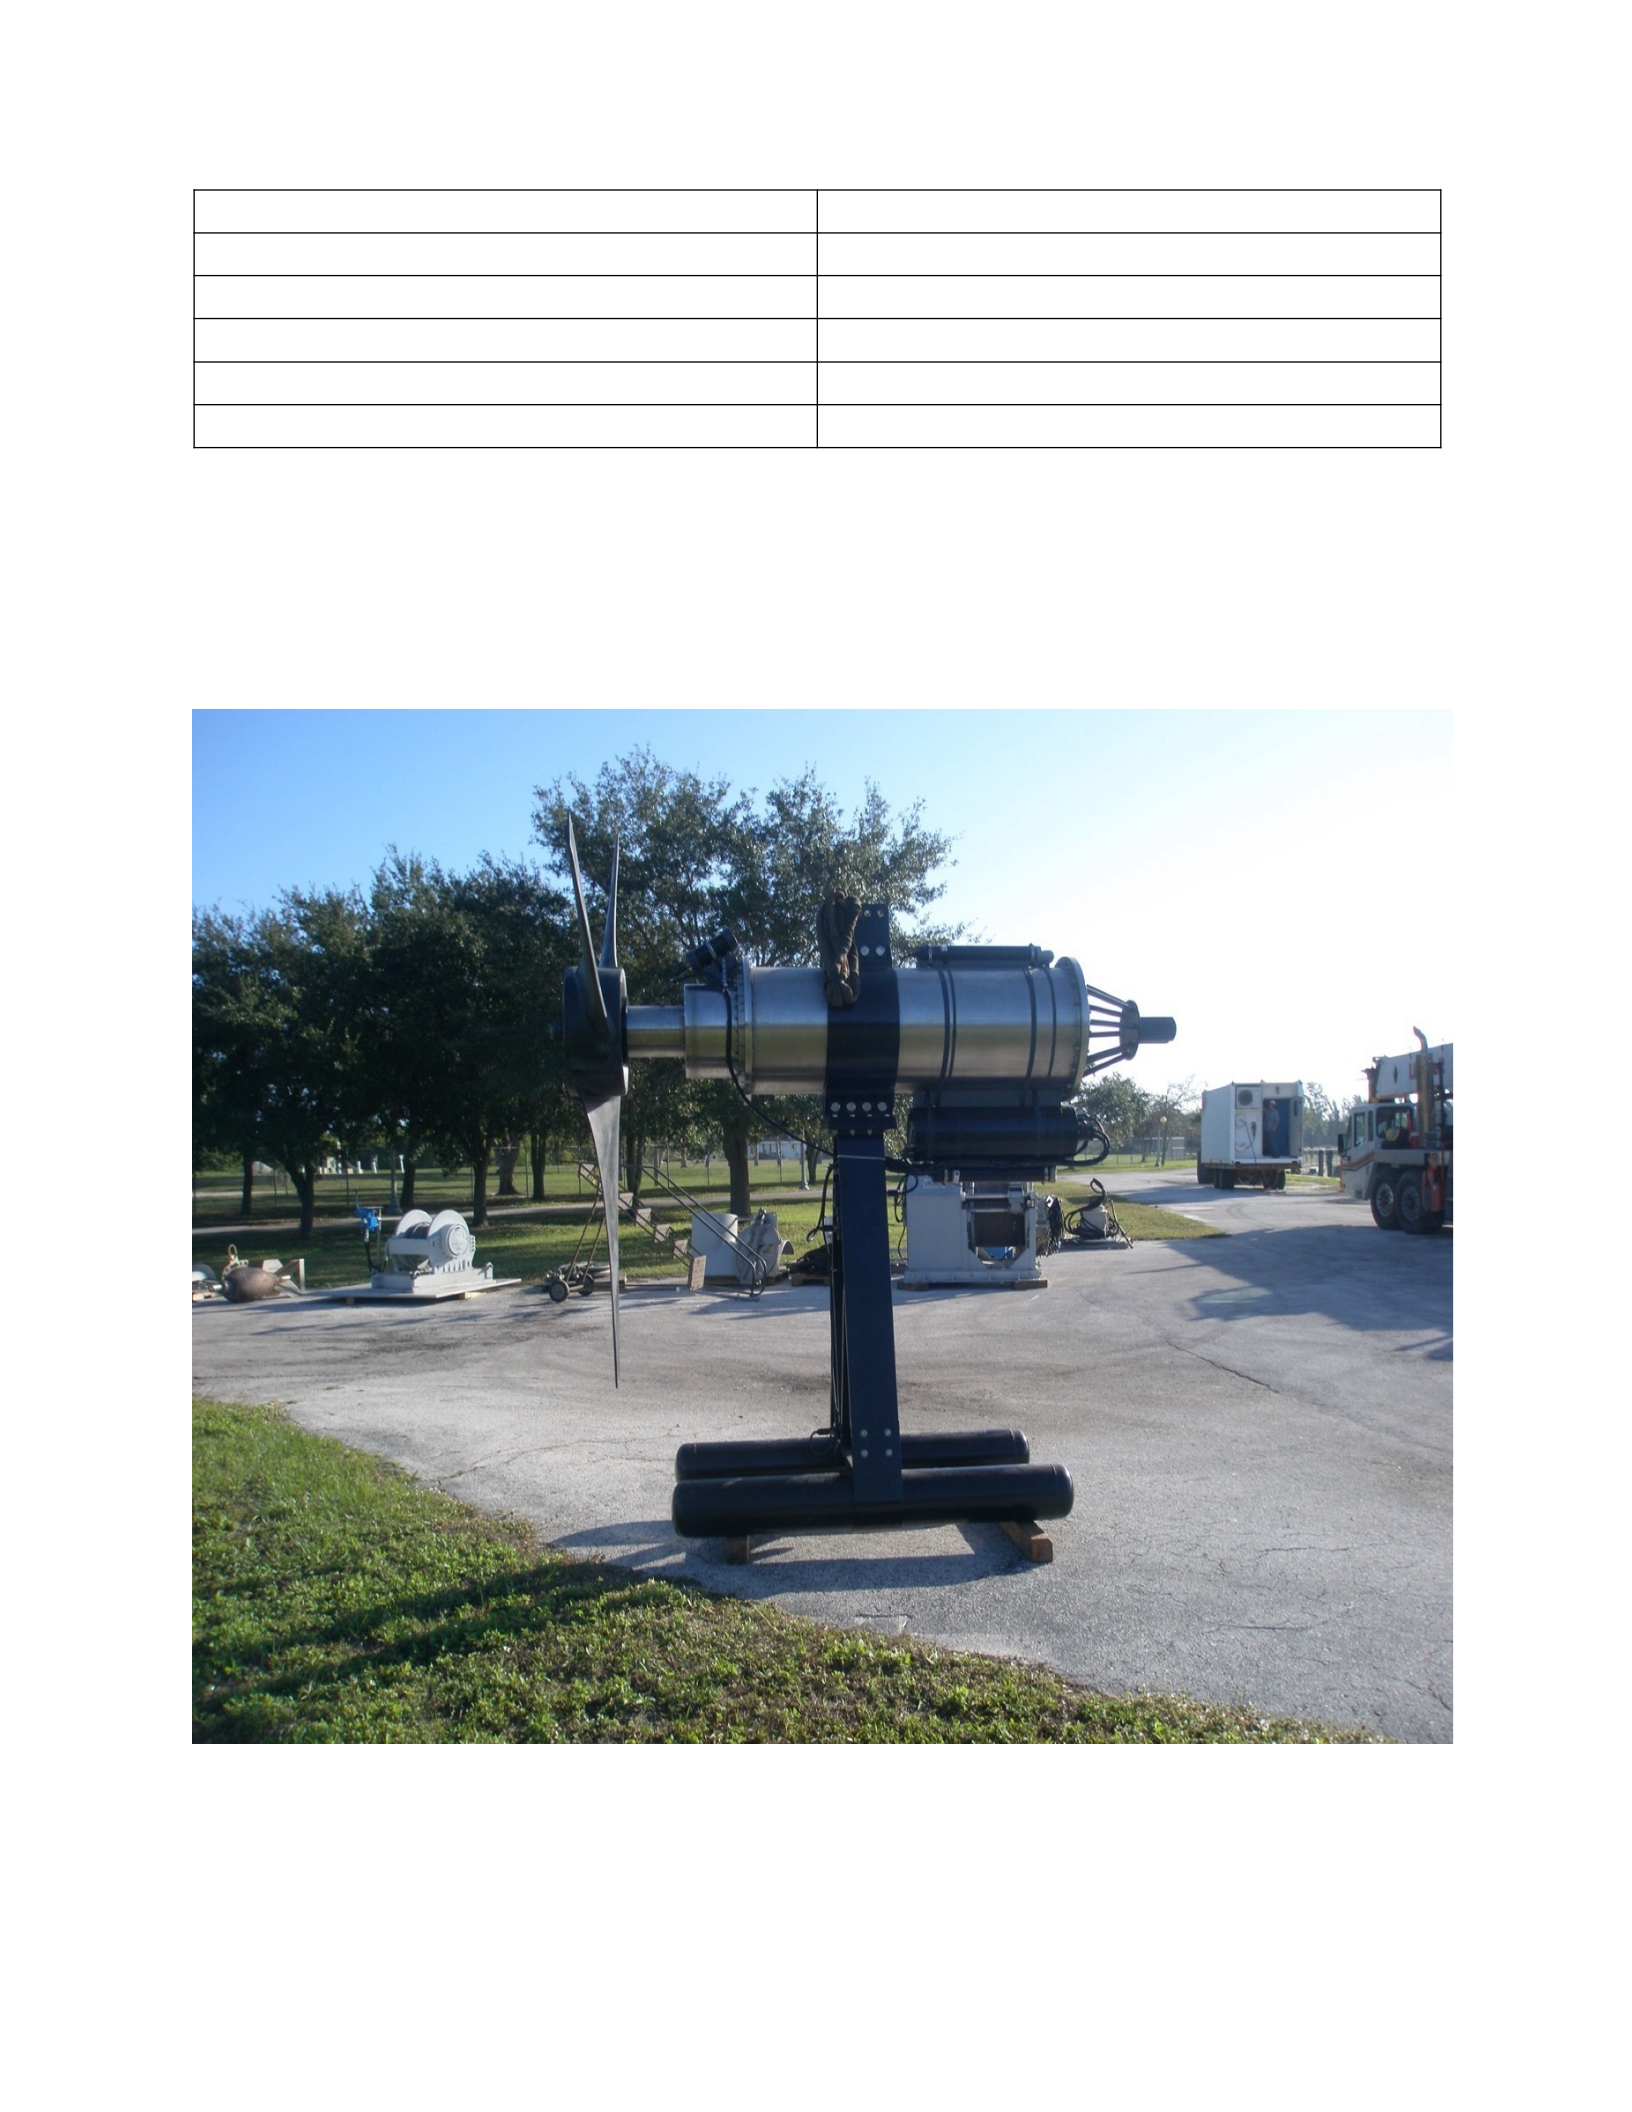
Table 2.2 (Full-Scale Turbine Characteristics)
Table 2.2 illustrates the actual size propeller design information (73).
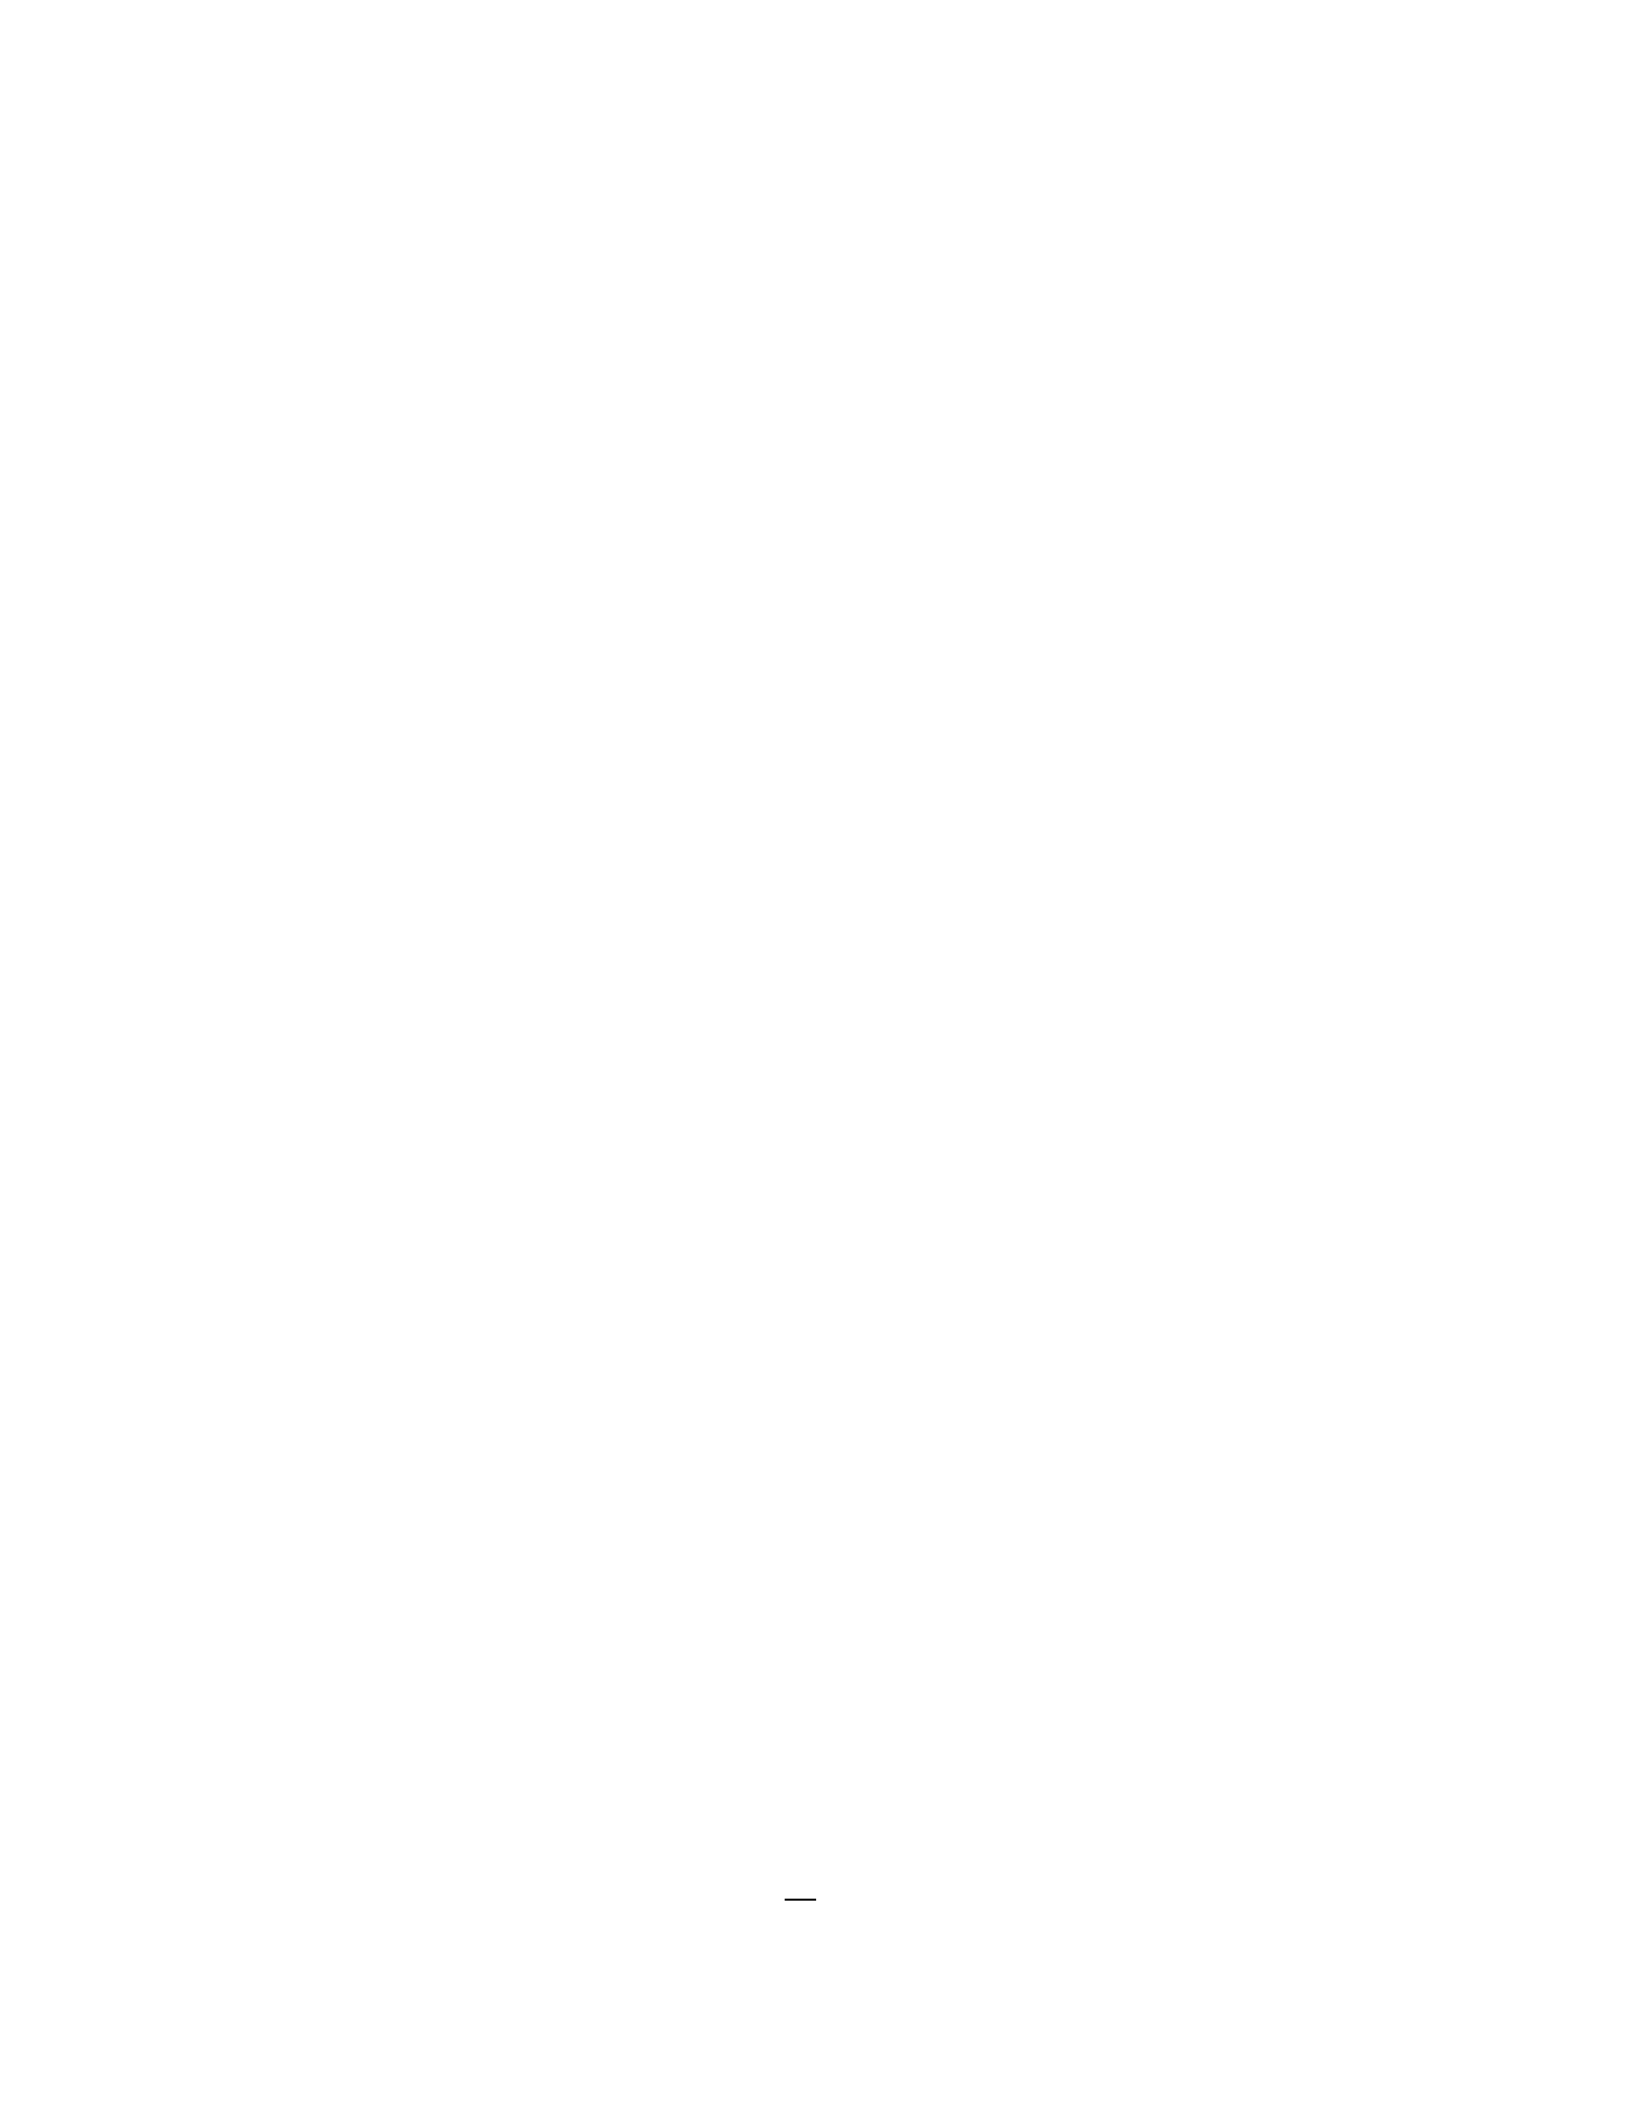
Figure 2.2 Full-Scale OCT (Photo taken by Dr. VanZweieten)
12
Figure 2.2 shows the actual size of an underwater current turbine run by Florida Atlantic
University. The rotor is attached to the downstream side of the turbine which means it is at the
rear of the turbine during operation.
Oceanography, marine engineering, and naval architecture are just a few of the engineering
fields that rely heavily on the study of hydrodynamics. Towing tanks, which provide a controlled
environment for checking fluid flow around the propeller at various operating states, are often
used in research to better understand the hydrodynamic behavior of the propeller. However,
testing a giant propeller at full scale can be expensive and difficult. To evaluate hydrodynamic
performance in a laboratory context, degrading the model while maintaining similarity is a
realistic strategy. we present the scale-down procedure used to conduct experiments in tow tanks
at the University of New Orleans. The goal of scaling is to investigate the hydrodynamic
performance of the propeller at reduced dimensions, while maintaining similarity with the full-
scale model.
The scale-down method used in the design and analysis of hydrokinetic systems uses the
advanced ratio (J) as a critical parameter. The advanced ratio, commonly denoted as J, is a
fundamental metric in hydrokinetic energy extraction that characterizes the rotational speed of
the rotor relative to the velocity of the flowing fluid. In the context of ocean current turbines,
advanced ratios serve as a key indicator of the turbine's operating conditions, helping to assess
its performance at different rotational speeds. The utilization of advanced ratios in scale-down
methods allows researchers to model and analyze hydrokinetic systems under controlled
laboratory conditions, providing insight into turbine behavior in a variety of operational
scenarios.
The importance of advanced ratios in hydrokinetic energy research is well documented in the
scientific literature. The study emphasizes the importance of advanced ratios in predicting and
optimizing turbine performance. The advanced ratio is closely related to the concept of tip speed
ratio, which plays an important role in determining the efficiency of energy conversion from
fluid flow to mechanical power. Insights from this study contribute to a more nuanced
understanding of the interaction between rotor speed and fluid velocity, informing the scale-
down methodology used in laboratory experiments. (81-86)
Furthermore, the application of advanced ratio-based scaling is supported by computational
methods and numerical simulations. Several studies have shown the integration of advanced
ratio considerations in computational models to accurately predict the performance of
hydrokinetic systems. This integration facilitates a comprehensive analysis of the turbine's
response to various flow conditions and rotational speeds, aligned with the goal of the scale-
down method. (87-92)
In summary, the scale-down method in hydrokinetic energy research, utilizing advanced ratios
as a key parameter, takes advantage of the wealth of knowledge and insights provided by
scientific studies. The role of advanced ratios in predicting and optimizing turbine performance,
as highlighted in the literature, underlies the reason for their incorporation into scale-down
methodologies. By leveraging these principles, researchers can conduct controlled experiments
in a scaled laboratory setting, gaining valuable insights into the behavior of hydrokinetic systems
and their potential for renewable energy extraction.
J = V
Nd
(2.1)
13
where V is the free flow velocity,
D is the diameter of the propeller, and
n is the speed of rotation of the propeller (rev/s)).
The forward ratio is the ratio of the actual fluid distance of the propeller (V) to the theoretical
distance to be traveled in a single revolution at the current rotational speed nD. Because it
describes the working position of the propeller and directly affects how efficient its
hydrodynamics are, it is an important parameter.
The low forward ratio (J<<1) causes the propeller to experience low axial flow velocity
compared to rotational speed, which decreases the generation of thrust. The propeller travels
more effectively, generates more thrust and more efficiently moves the vehicle or vessel through
the fluid as the forward ratio rises (J approaches and exceeds 1).
Summer Country Froude (Fr):
Fr = V
√%&
(2.2)
where V is the free flow
velocity, D is the diameter of
the propeller.
Froude Similarity (Fr) is a dimensionless parameter used in fluid dynamics to study the
behavior of objects, such as ships and propellers, in different fluid environments while
maintaining dynamic similarity. Froude's common number is named after William Froude, a
19th-century British naval engineer and architect. The Froude equation number is a measure of
the ratio of the inertial force to the gravitational force acting on an object in a fluid. It
characterizes the flow regime and helps predict the dynamic behavior of objects under similar
conditions in tanks or bodies of water of different sizes. to ensure an accurate representation of
the flow physics and propeller behavior in the towing tank.
The use of advanced ratios and Froude equations for scale-down procedures is a well-
established technique in hydrodynamic research. This allows us to extrapolate the experimental
results obtained in the tow tank to accurately compare with the performance of a full-scale
propeller in a real-world application. This scaling approach ensures that flow physics and
hydrodynamic characteristics remain consistent between the scaled-down model and the full-
scale propeller.
In the study of propellers and hydrodynamics, the forward ratio (J) and Froude similarity (Fr) are
important factors without dimensions. The effectiveness and performance of the propeller are
determined by the advanced ratio, and reliable scaling for experimental studies is possible by the
Froude similarity. Applications in marine engineering, naval architecture, and propulsion
systems can all be optimized primarily by knowing and using these factors.
The use of tow tanks in hydrodynamic research stands as a cornerstone in advancing our
understanding of fluid-structure interactions, especially in the context of marine propulsion
systems and renewable energy technologies. One of the main advantages associated with towing
tanks lies in their unparalleled ability to provide precise control over experimental conditions, an
important aspect that significantly improves the reliability and reproducibility of research results.
Among the factors subject to careful control are flow speed, propeller rotation speed, and various
environmental parameters, which contribute to the formation of a controlled and standardized
test environment. Tow tank at the University of New Orleans (UNO)
14
stands as a prime example of such a facility, providing a sophisticated platform to conduct
experiments in a controlled and replicable manner.
The ability to manipulate the flow velocity inside the towing tank plays an important role in
investigating the hydrodynamic performance of marine propulsion systems. By adjusting the
flow velocity, researchers can simulate a variety of real-world conditions, such as varying water
currents, allowing for comprehensive exploration of how different speeds affect the efficiency
and stability of the propeller. This dynamic control is essential for studies involving ocean
current turbines, where the interaction between turbine blades and variable flow velocity is an
important determinant of energy extraction efficiency. The ability to precisely control and
modulate the flow rate inside the towing tank at UNO allows the researchers to simulate a wide
variety of scenarios, ensuring a thorough examination of hydrodynamic phenomena under
different operating conditions.
In addition, the towing tank provides the ideal setup for investigating the influence of the
propeller rotation speed on the overall performance of the system. The rotation speed of the
propeller is a key parameter that affects its thrust, power consumption, and efficiency. By
manipulating and controlling the rotational speed of the propellers inside the tow tank,
researchers can systematically explore the impact of varying speeds on hydrodynamic forces,
cavitation, and overall propulsion efficiency. This level of control is critical for designing and
optimizing marine propellers for a wide range of applications, from ship propulsion to renewable
energy systems. The towing tank at UNO, equipped with a precise rotational speed control
mechanism, empowers researchers to conduct experiments that yield insights into the intricate
relationship between propeller design, rotational speed, and hydrodynamic performance.
Environmental parameters, such as water temperature, salinity, and ambient pressure, play a
crucial role in influencing the hydrodynamic behavior of marine systems. Tow tanks offer a
controlled environment where these parameters can be carefully adjusted to mimic specific
real-world conditions. This feature is particularly relevant for studies conducted in UNO's
towing tanks, where the design of the facility allows the manipulation of environmental
variables to replicate scenarios encountered in diverse marine environments. Researchers can
systematically investigate how changing environmental conditions affect the performance and
efficiency of marine propulsion systems, shedding light on the adaptability and resilience of
these systems in a variety of operational contexts.
The tow tank at the University of New Orleans exemplifies a state-of-the-art facility that
embodies this advantage. Equipped with state-of-the-art instrumentation and control systems,
UNO's towing tanks provide researchers with a versatile and dynamic platform for conducting
experiments in a controlled environment. The facility's ability to precisely regulate flow speed,
propeller rotation speed, and environmental parameters ensures reliable and reproducible data
production, fostering a deeper understanding of hydrodynamic phenomena.
UNO's towing tanks not only facilitate fundamental research but also serve as a valuable tool for
developing and validating innovative technologies in the field of marine propulsion and
renewable energy. The controlled conditions offered by the towing tanks, coupled with the
advanced capabilities of UNO facilities, position them as a key asset in advancing the
boundaries of hydrodynamic research and marine engineering. ((https://
www.uno.edu/academics/coe/name/facilities/towing-tank))
15
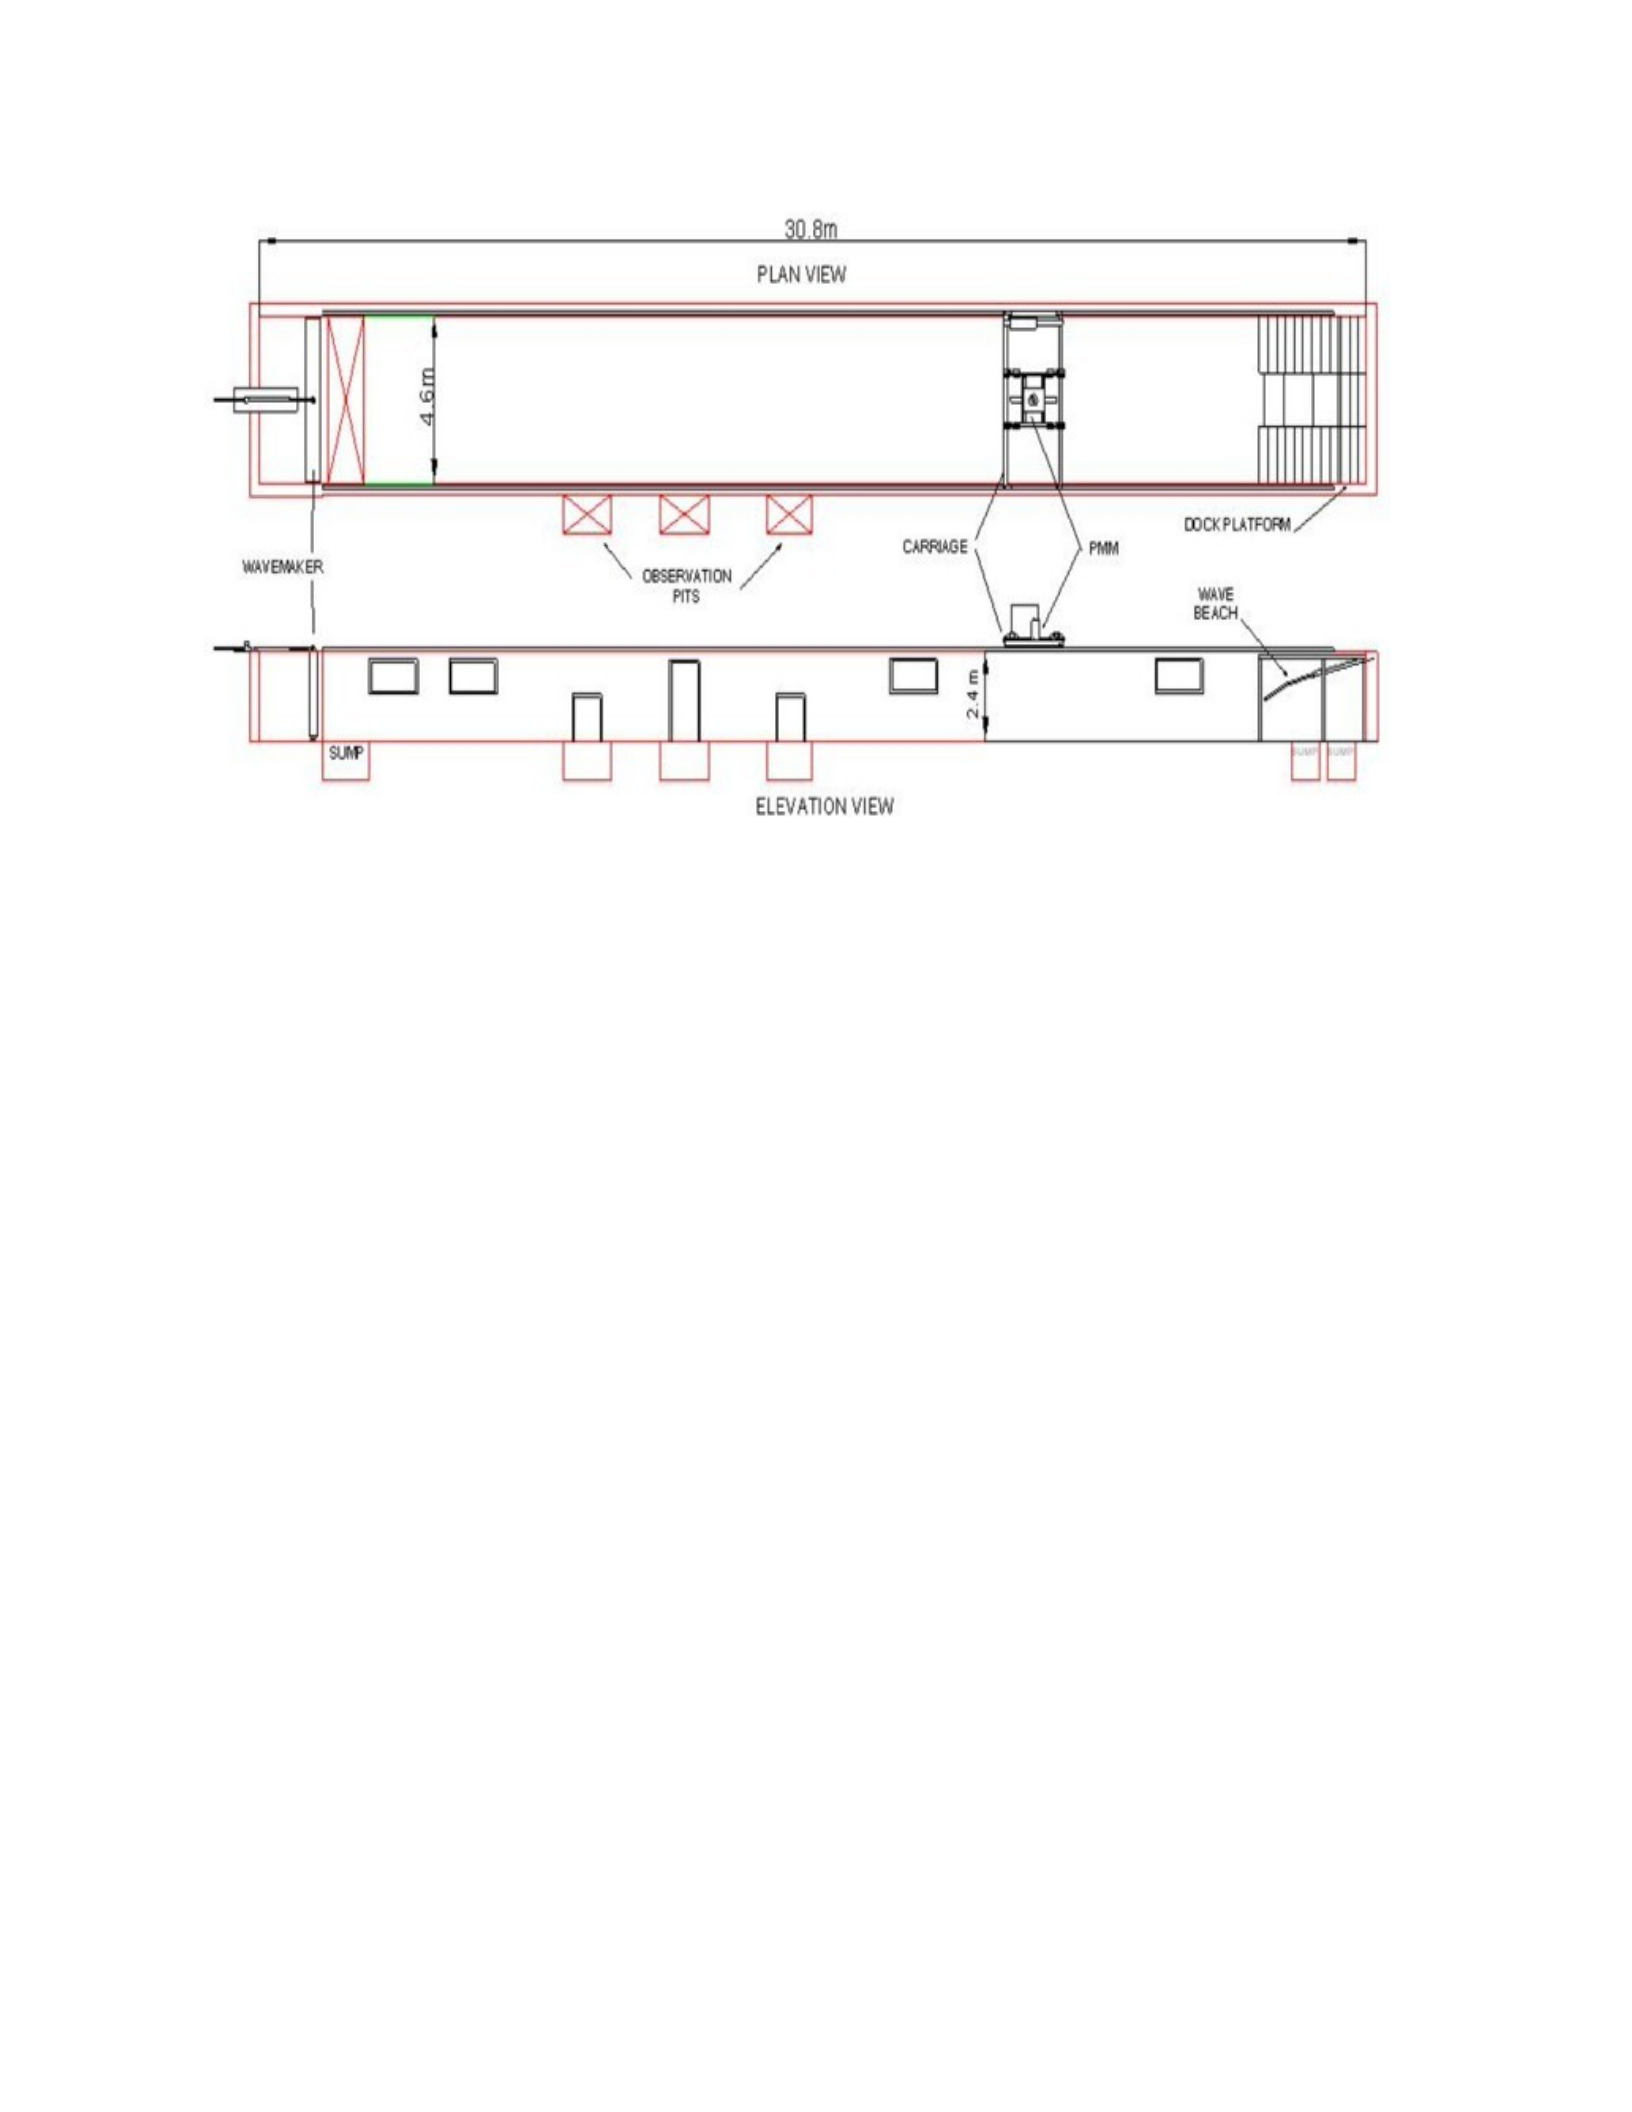
Fig.2.3. Dimensions of the towing tank of the UNO.
The restrictions imposed on the forward ratio (J), current velocity (V), and Reynolds number (Re) are
very important in determining the operating conditions and hydrodynamic performance of the propeller
in this study. Operating within this specific range ensures that the results of the experiment are
representative of real-world conditions and allows for a more accurate and in-depth analysis of the
propeller behavior on different flow regimes and operating conditions.
In our particular study, the calculated down payment ratio was limited to a range of 0.032 ≤ J ≤
0.79. The propeller is used at a relatively low forward speed in relation to its rotational speed and
diameter, as indicated by the lowest limit of 0.032 (J> 0.032). In this case, the propeller runs inefficiently
and produces less thrust for a given rotational speed. Top
The forward ratio limit of 0.79 (J ≤ 0.79) conveys that the propeller operates more efficiently, with a
more significant proportion of forward speed to rotation speed. When the propeller operates within this
range of advanced ratios, it can produce higher thrust and provide better propulsion performance.
The current velocity (V) represents the speed at which the free flow of water is operated by the vane.
Based on a small-scale analysis, the most suitable current velocity for trains was found to be limited to
a range of 0.1 m/s ≤ V ≤ 2,450 m/s. At the lower limit of train speed of 0.1 m/s (V ≥ 0.1 m/s), the
propeller operates in a generally calm stream of water with low current velocities. In this scenario, the
propeller may experience an overall decrease in performance due to the limited amount of kinetic
energy in the fluid. An upper limit of 2,450 m/s (V ≤ 2,450 m/s) indicates that the propeller operates in
conditions of faster flowing water. In this regime, the propeller experiences a higher flow rate, which
can potentially lead to increased thrust and better performance.
The Reynolds number (Re) is defined as the ratio of inertial force to viscous force and is expressed as a
dimensionless parameter used to characterize the flow regime around the propeller and according to the
scale reduction procedure is given as 2×10⁴ ≤ Re ≤ 2× 10⁵ in this study.
16
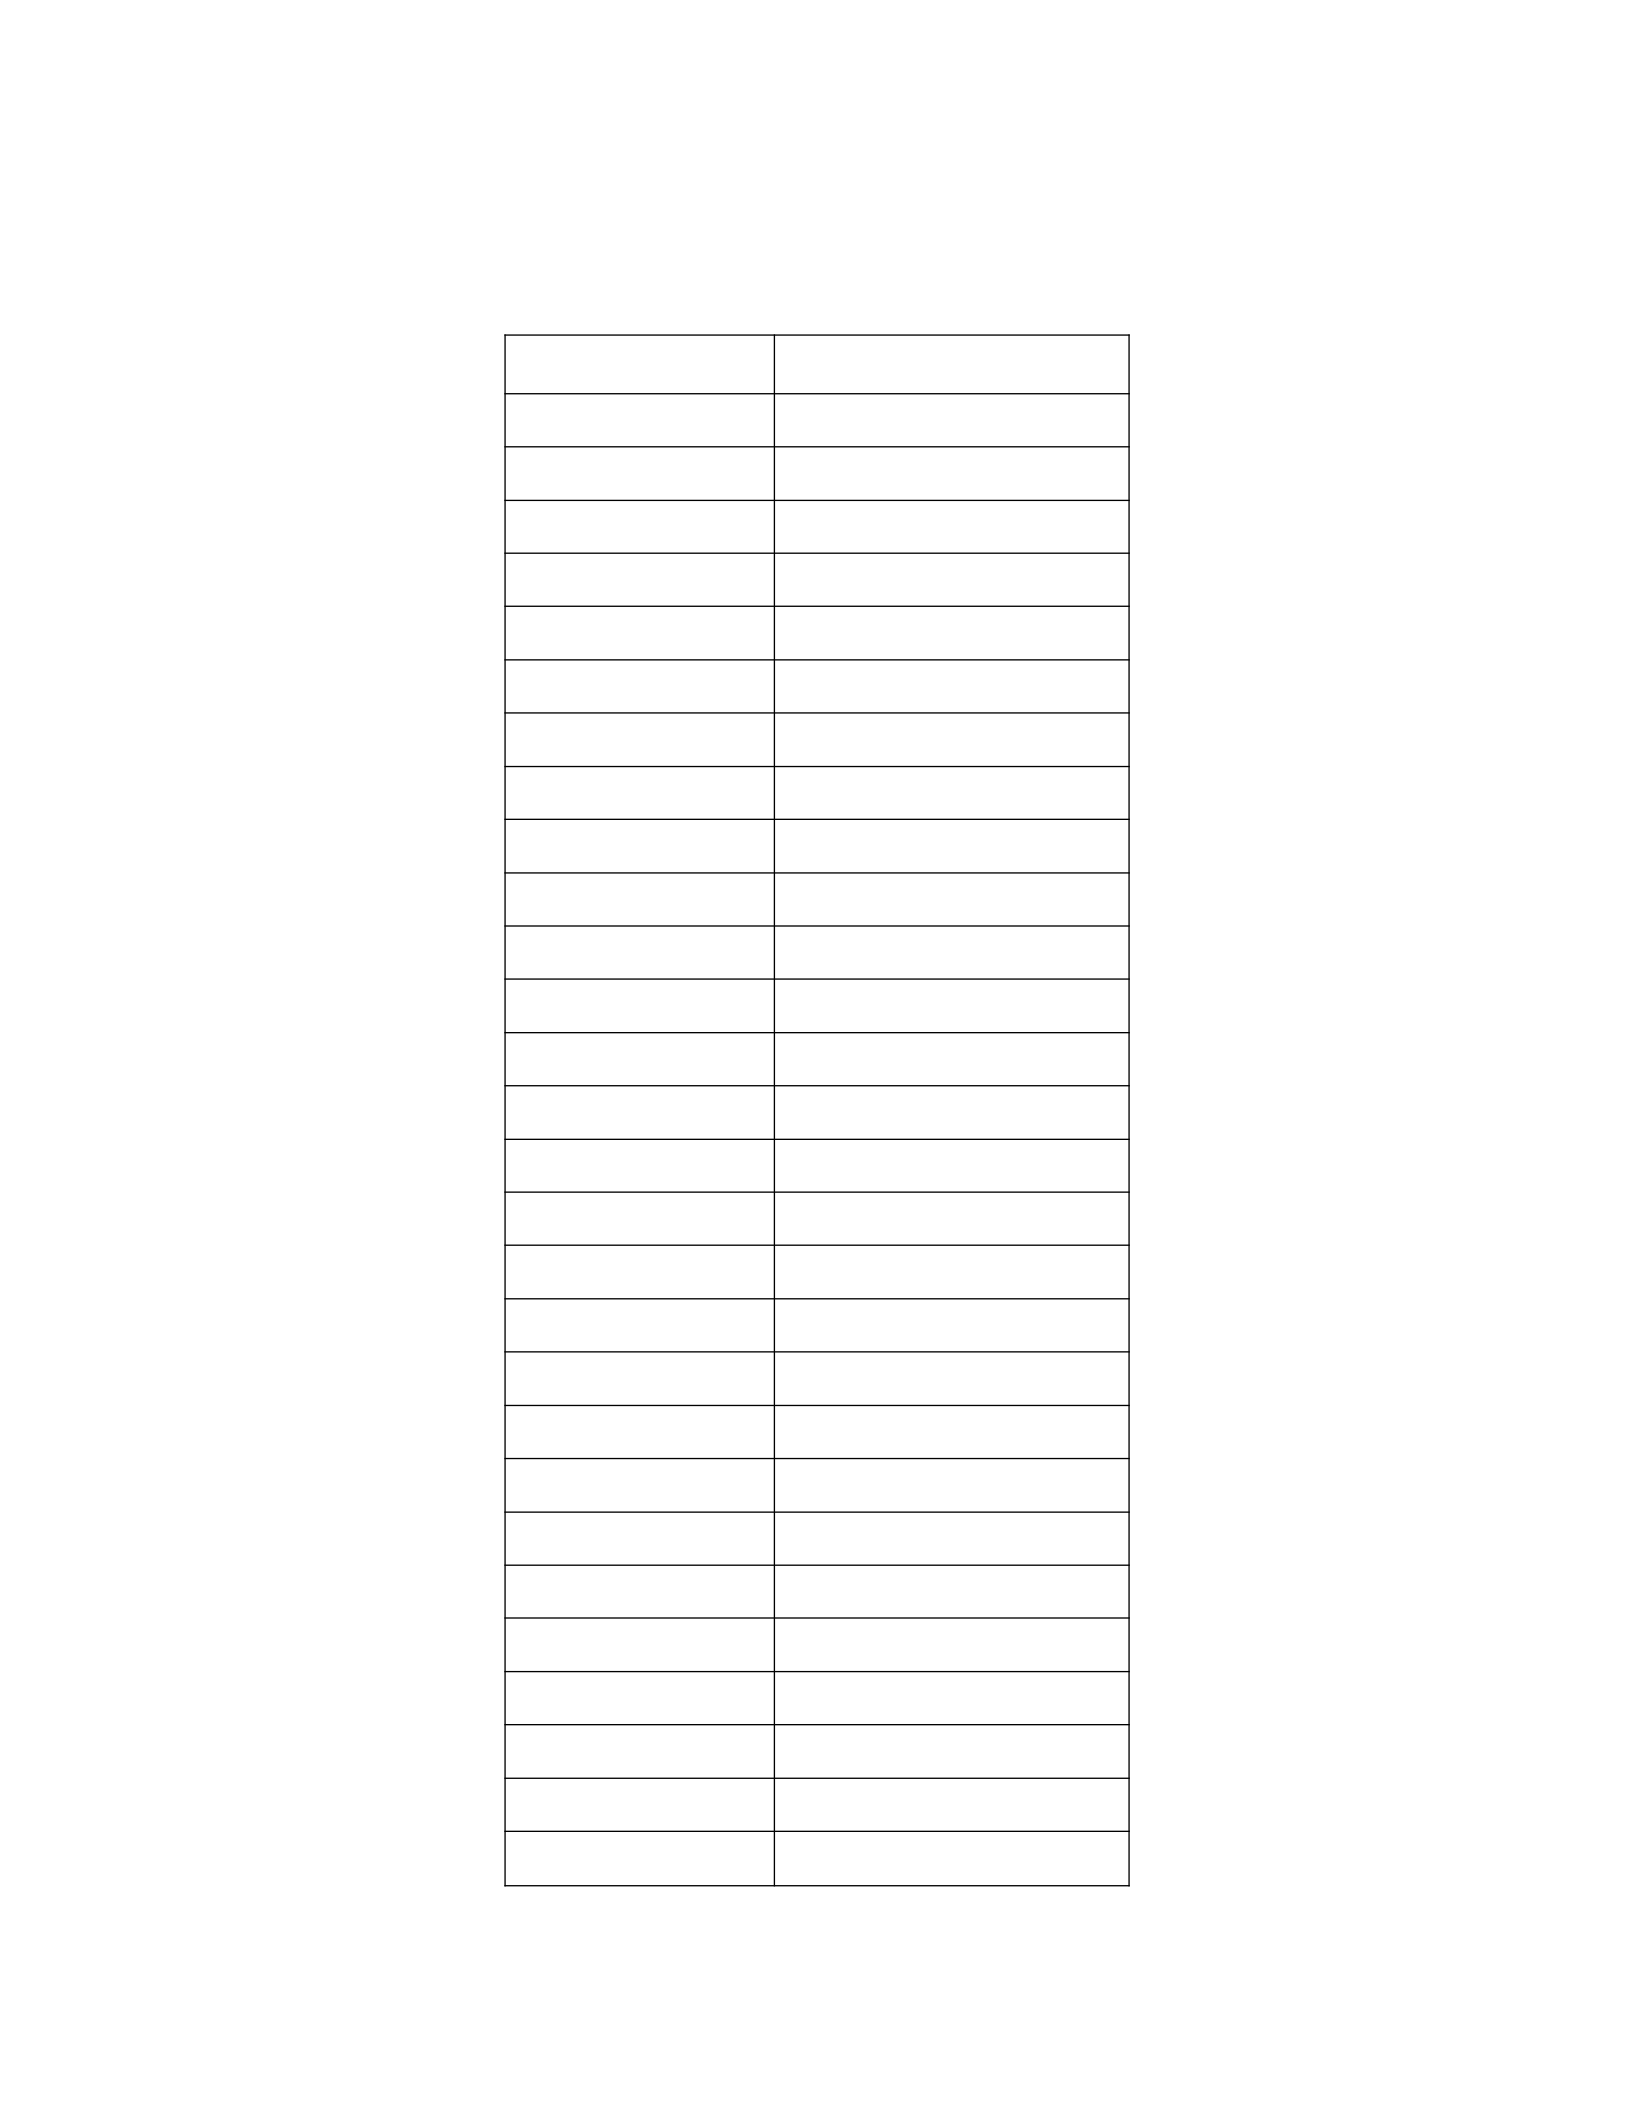
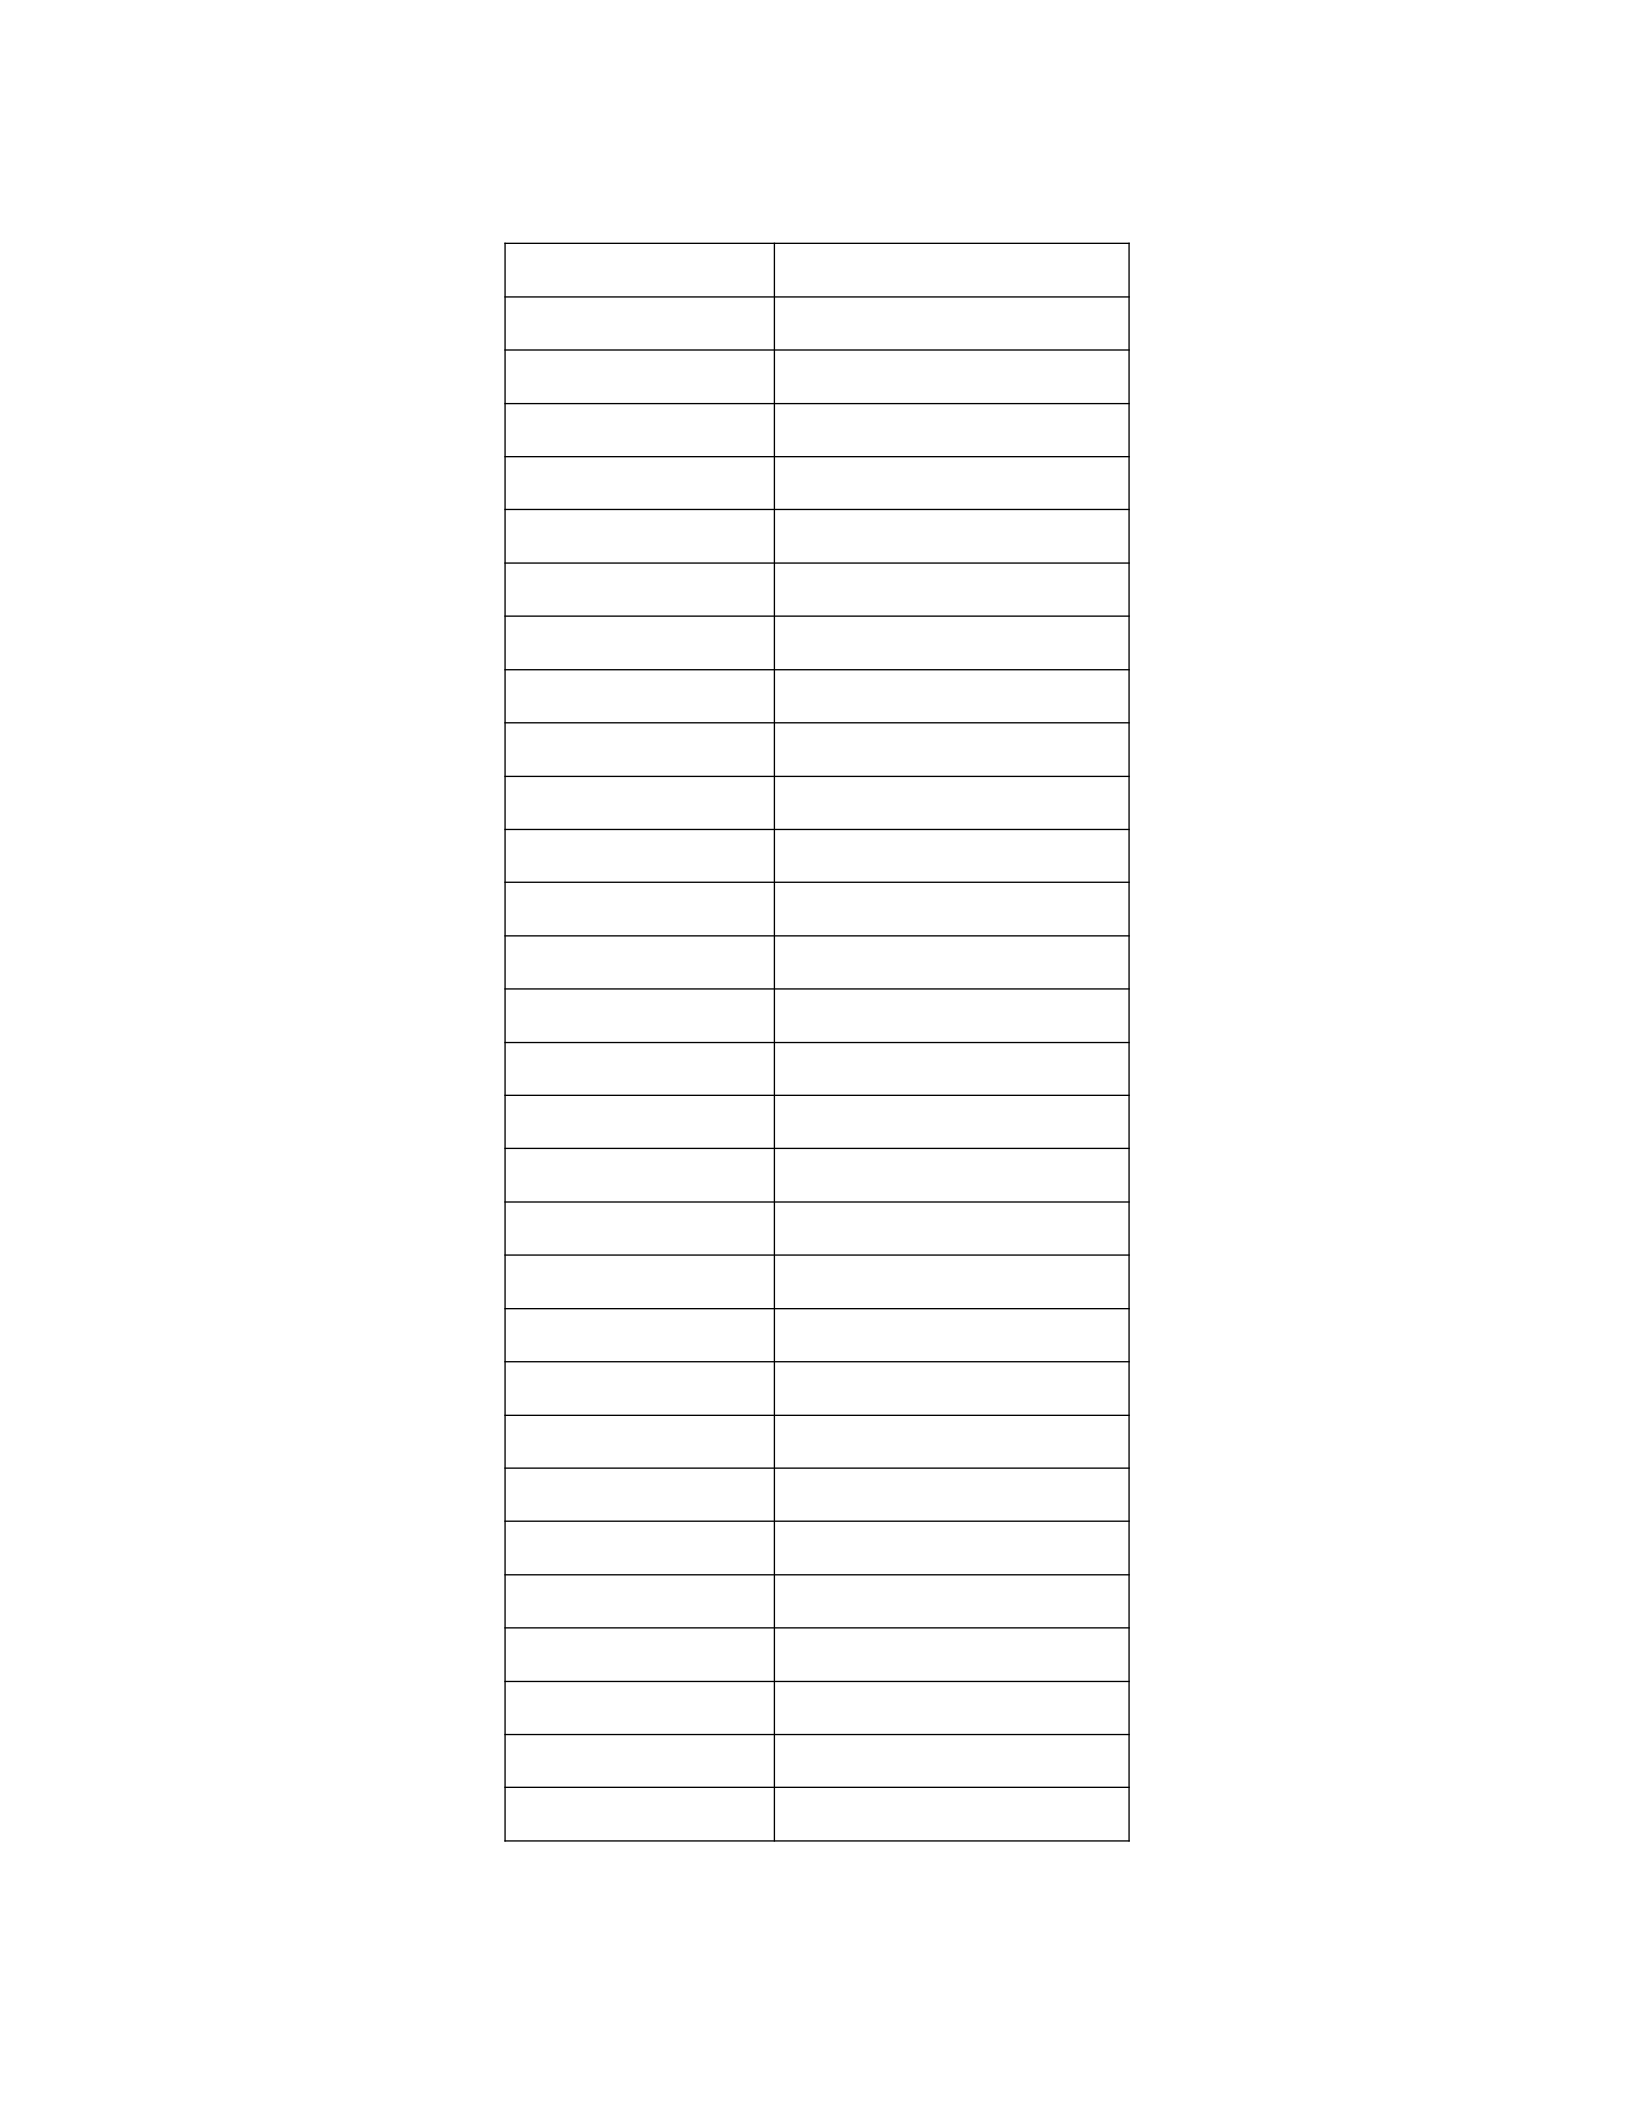
Speed (m/s) Reynolds Number
0.365 29425.57
0.4015 32368.127
0.438 35310.684
0.4745 38253.241
0.511 41195.798
0.5475 44138.355
0.584 47080.912
0.6205 50023.469
0.657 52966.026
0.6935 55908.583
0.73 58851.14
0.7665 61793.697
0.803 64736.254
0.8395 67678.811
0.876 70621.368
0.9125 73563.925
0.949 76506.482
0.9855 79449.039
1.022 82391.596
1.0585 85334.153
1.095 88276.71
1.1315 91219.267
1.168 94161.824
1.2045 97104.381
1.241 100046.938
1.2775 102989.495
1.314 105932.052
1.3505 108874.609
17
1.387 111817.166
1.4235 114759.723
1.46 117702.28
1.4965 120644.837
1.533 123587.394
1.5695 126529.951
1.606 129472.508
1.6425 132415.065
1.679 135357.622
1.7155 138300.179
1.752 141242.736
1.7885 144185.293
1.825 147127.85
1.8615 150070.407
1.898 153012.964
1.9345 155955.521
1.971 158898.078
2.0075 161840.635
2.044 164783.192
2.0805 167725.749
2.117 170668.306
2.1535 173610.863
2.19 176553.42
2.2265 179495.977
2.263 182438.534
2.2995 185381.091
2.336 188323.648
2.3725 191266.205
2.409 194208.762
2.4455 197151.319
18
2.482 200093.876
Table 2.3
Re = ρVL =
VL (2.3)
M 𝜐
Mana:
Re is Reynolds' number (dimensionless) ρ is
the density of the fluid (kg/m³)
V is the velocity of the fluid (m/s)
L is the characteristic length scale (e.g., the diameter of the
propeller) μ is the dynamic viscosity of the fluid (kg/(m·s) or Pa.s)
υ is the kinematic viscosity of the fluid (m^2⁄s)
At the upper limit (Re ≥ 2×10^5), the flow around the propeller is in a turbulent regime.
Turbulence can increase mixing and can lead to increased drag, which affects the overall
performance of the propeller. The transition or laminar regime is indicated by the lower
boundary (Re ≥ 2×10^4), Flow is usually smoother in this region, and the propeller may face
fewer obstacles and more consistent behavior.
2.1 Analysis of Lift and Resistance Coefficients vs. Attack Angles
(−10° ≤ α ≤16) Based on JavaFoil and AirFoilTools (FX-77-W121)
In the field of aerodynamics, the tools used to analyze and design airfoils play a crucial role in
advancing our understanding of the intricate relationship between fluid dynamics and geometric
configurations. Among these tools, JAVAFOIL and AirfoilTools emerged as different platforms,
each characterized by unique features, capabilities, and methodologies. Understanding the
nuances of these tools requires exploring their operational mechanisms, uses, and applications in
the context of broader aerodynamic research.
JAVAFOIL, a computing software with a focus on airfoil analysis and aerodynamic prediction,
distinguishes itself by being a standalone program that is usually installed on the user's computer
or a specialized computing environment. This installation process requires users to download and
set up the software before taking advantage of its capabilities. The software, which is rooted in
the principles of the panel method or the boundary element method, relies on numerical
techniques to calculate important airfoil characteristics such as lift and drag coefficients, pressure
distribution, and flow patterns around the hydrofoil. To start the analysis using JAVAFOIL, the
user usually enters the coordinates of the airfoil, and the software performs a detailed

19
examination through numerical simulation. This approach makes JAVAFOIL invaluable for
users seeking in-depth numerical analysis of airfoil performance, especially when calculating lift
and drag coefficients for specific airfoil geometries is essential.

20
On the other hand, AirfoilTools distinguishes itself as a web-based platform, operating
seamlessly within a web browser. The main advantage here lies in its accessibility; users can
access AirfoilTools through a web browser without the need for prior installation. This web-
based nature makes AirfoilTools user-friendly and immediately available to anyone with an
internet connection and a web browser. While JAVAFOIL leans towards advanced users who
need detailed aerodynamic analysis and are familiar with the operation of the software,
AirfoilTools caters to a wider audience, serving as a quick reference for airfoil data, comparison,
and visualization.
JAVAFOIL's emphasis on providing detailed aerodynamic insights is reflected in its
requirements for users to have access to the software and a certain level of familiarity with its
operations. This makes JAVAFOIL an ideal choice for researchers and engineers who need a
tool that offers flexibility and sophistication in aerodynamic analysis. This software is invaluable
when complex investigations into airfoil performance are required, making it the preferred
choice for those involved in detailed design and optimization of aerodynamic components.
In contrast, AirfoilTools takes a different approach by offering a variety of airfoil data and
analysis tools through a web-based interface. Users can explore the airfoil coordinate database,
compare different airfoils, and visualize the shape of the airfoil without the need for software
installation. The platform's accessibility makes it a valuable resource for initial airfoil selection,
airfoil database exploration, and educational purposes. AirfoilTools is becoming the go-to tool
for individuals looking for instant access to airfoil data and perform quick analysis without the
hassle associated with software installation and operation.
Examining the methodology of these tools reveals fundamental differences in their operational
paradigm. JAVAFOIL, using the panel method or the boundary element method, is deeply rooted
in numerical simulation. This computational approach allows for a comprehensive analysis of
airfoil behavior under a variety of conditions. The software's reliance on user-supplied airfoil
coordinates sets the stage for detailed numerical simulations, offering a wealth of data related to
lift and drag coefficients, pressure distribution, and flow patterns. Therefore, JAVAFOIL caters
to users who prioritize accuracy and specificity in their aerodynamic analysis.
In contrast, AirfoilTools operates as an airfoil data repository, utilizing a database-centric
approach. The platform stores a wide array of airfoil coordinates, facilitating basic comparison,
visualization, and analysis. While AirfoilTools does provide important aerodynamic data such as
drag and lift coefficients, its main strength lies in offering a user-friendly interface for quick
reference and exploration. The web-based nature of AirfoilTools simplifies access to a wealth of
airfoil information, making it an attractive option for those who prioritize ease of use and broad
accessibility.
Considering the user experience, JAVAFOIL needs a more direct approach. Users must navigate
through the installation process, ensure compatibility with their computing environment, and
have a certain level of familiarity with the functionality of the software. However, the investment
in understanding this software pays off for users who need powerful tools for complex
aerodynamic analysis. JAVAFOIL's interface, while potentially daunting for beginners, provides
users with an important level of control and flexibility for a detailed investigation of airfoil's
performance.
In contrast, AirfoilTools adheres to a more user-friendly approach, taking advantage of the
convenience of web-based accessibility. The platform's intuitive interface allows users to explore
airfoils

21
database, visually compare different airfoils, and retrieve important aerodynamic data with
minimal effort. AirfoilTools caters to a wider audience by removing the bottlenecks associated
with the installation process and system compatibility. This inclusivity makes it an ideal choice
for educational purposes, where simplicity and accessibility are important considerations.
Moreover, the different advantages offered by these tools go beyond their basic functions.
JAVAFOIL, with its emphasis on detailed numerical analysis, positions itself as the preferred
choice for researchers involved in advanced aerodynamic studies. The software's ability to
calculate lift and drag coefficients with precision, coupled with its focus on hydrofoil analysis, is
aligned with the needs of those working on complex aerodynamic problems. JAVAFOIL is a
valuable asset for projects that require a deeper understanding of the aerodynamic forces that
play a role in various airfoil configurations.
In contrast, AirfoilTools serves as a versatile platform that caters to a wide range of users with
diverse needs. Its role as an airfoil data repository, comparison tool, and visualization feature
makes it an excellent resource for initial investigation and quick reference. Designers, students,
and enthusiasts alike can benefit from the platform's accessibility, using it as a starting point to
explore airfoil characteristics, compare designs, and gain insight into basic aerodynamic
principles.
The advantages of these tools are further underlined by their application in specific contexts. For
example, JAVAFOIL's advanced capabilities make it an invaluable tool for researchers and
engineers involved in the design and optimization of propulsion systems, where a detailed
understanding of airfoil performance is essential. The software's focus on numerical simulation
and hydrofoil analysis aligns with the demands of projects seeking to maximize efficiency and
performance in challenging fluid environments.
In contrast, AirfoilTools finds its niche in scenarios where accessibility and ease of use are
paramount. Designers and students, especially those in the early stages of their projects, can
utilize AirfoilTools to quickly explore airfoil options, compare designs, and visualize shapes.
The platform's extensive airfoil database and easy interface make it a versatile tool for
educational purposes, providing a resourceful platform for learning about aerodynamics without
learning the complexities associated with sophisticated computing software.
The advantages and different methodologies of JAVAFOIL and AirfoilTools reflect the broader
tool landscape available in aerodynamics. While JAVAFOIL targets a more niche audience
looking for advanced numerical analysis, AirfoilTools takes a more inclusive approach, catering
to a wider spectrum of users. Both tools contribute significantly to the field, providing valuable
resources for researchers, engineers, students, and enthusiasts. Their complementary role in
aerodynamics toolkits highlights the importance of having a wide range of tools that can meet
specific needs at different stages of the design and analysis process.
In conclusion, JAVAFOIL and AirfoilTools emerged as invaluable assets in the field of
aerodynamics, offering distinctive features and methodologies tailored to the needs of diverse
users. JAVAFOIL, with its emphasis on advanced numerical analysis and hydrofoil-specific
applications, serves as a powerful tool for researchers.
2.2 Panel Method:
The Panel Method, also known as the Boundary Element Method, is a numerical technique
used in computational fluid dynamics (CFD) and aerodynamics to analyze and simulate flow

22
around objects, especially airfoils and wings. It is based on the concept of discrete the surface of
an object into small panels and treating each panel as a source or absorber of fluid velocity. In
this method, the surface of an object such as a hydrofoil will be divided into a limited number of
elements or panels. These panels are usually flat and close to the shape of the object's surface.
Also, the Panel Method is based on the theory of potential flow, which assumes that the flow of
an ideal fluid that cannot be compressed is an irritant and can be explained by the potential
velocity. This means that there are no vortices or rotational effects in the flow. In this method,
each panel is assumed to act as a source or absorber of fluid velocity. Source panels emit liquid
from their surfaces, whereas sink panels absorb liquids onto their surfaces. These panels are used
to represent the distribution of the source and sink on the surface of the object. To ensure
physical accuracy, a special condition called the Kutta condition is applied to the back edge of
the airfoil. This condition states that the speed at the rear edge is finite and not zero, preventing
unrealistic vortices from occurring there.
The Panel method calculates the source and sink strength (intensity) on each panel and its
effect on the velocity field across the flow domain. This is usually done iteratively until the
solution is integrated. The velocity at any point in the flow domain is calculated as the
superposition of the velocity induced by all panels on the surface. This process involves
integrating the influence of each panel into the entire surface. Once the velocity field is
determined, the pressure distribution on the surface of the object can be calculated using the
Bernoulli equation and the assumption of an inviscid flow that cannot be compressed. The Panel
Method allows the calculation of lift and drag on objects by integrating pressure distribution over
the surface. Lift is a force perpendicular to the direction of flow and resistance is a force parallel
to the direction of flow. The Panel Method is widely used in aerospace and hydrodynamic
engineering for the analysis of airfoils, wings, hulls, and other objects in fluid flows. It provides
valuable insights into aerodynamic performance, such as lift, drag, and pressure distribution. In
case of limitations, the panel method is based on several simplification assumptions, including
the absence of turbulence, viscosity, and three-dimensional effects. It is most accurate for
analyzing potential flow problems and may not accurately capture some complex flow
phenomena.
Each hydrodynamic force is a function of the free-flow velocity, fluid density, angle of attack,
fluid viscosity and free-flow sonic velocity.
F = fn(V∞, ρ, α, μ, a∞). (2.4)
Where
V
'
is the speed of free flow
,
ρ is the density of the fluid,
α is the angle of attack,
μ is the viscosity of the fluid and,
a
'
is free streaming sonic speed
.
The lift and drag coefficients for airfoils are the basic aerodynamic parameters used to describe
the performance of an airfoil (the cross-sectional shape of a wing or blade) in a liquid, usually
water. This coefficient is a dimensionless value that characterizes the ability of an airfoil to
produce lift (force perpendicular to the direction of flow) and drag (force parallel to the
direction of flow) when subjected to fluid flow, such as the motion of an airplane or the blades
of a wind turbine. Here are the scientific definitions for lift and resistance coefficients:
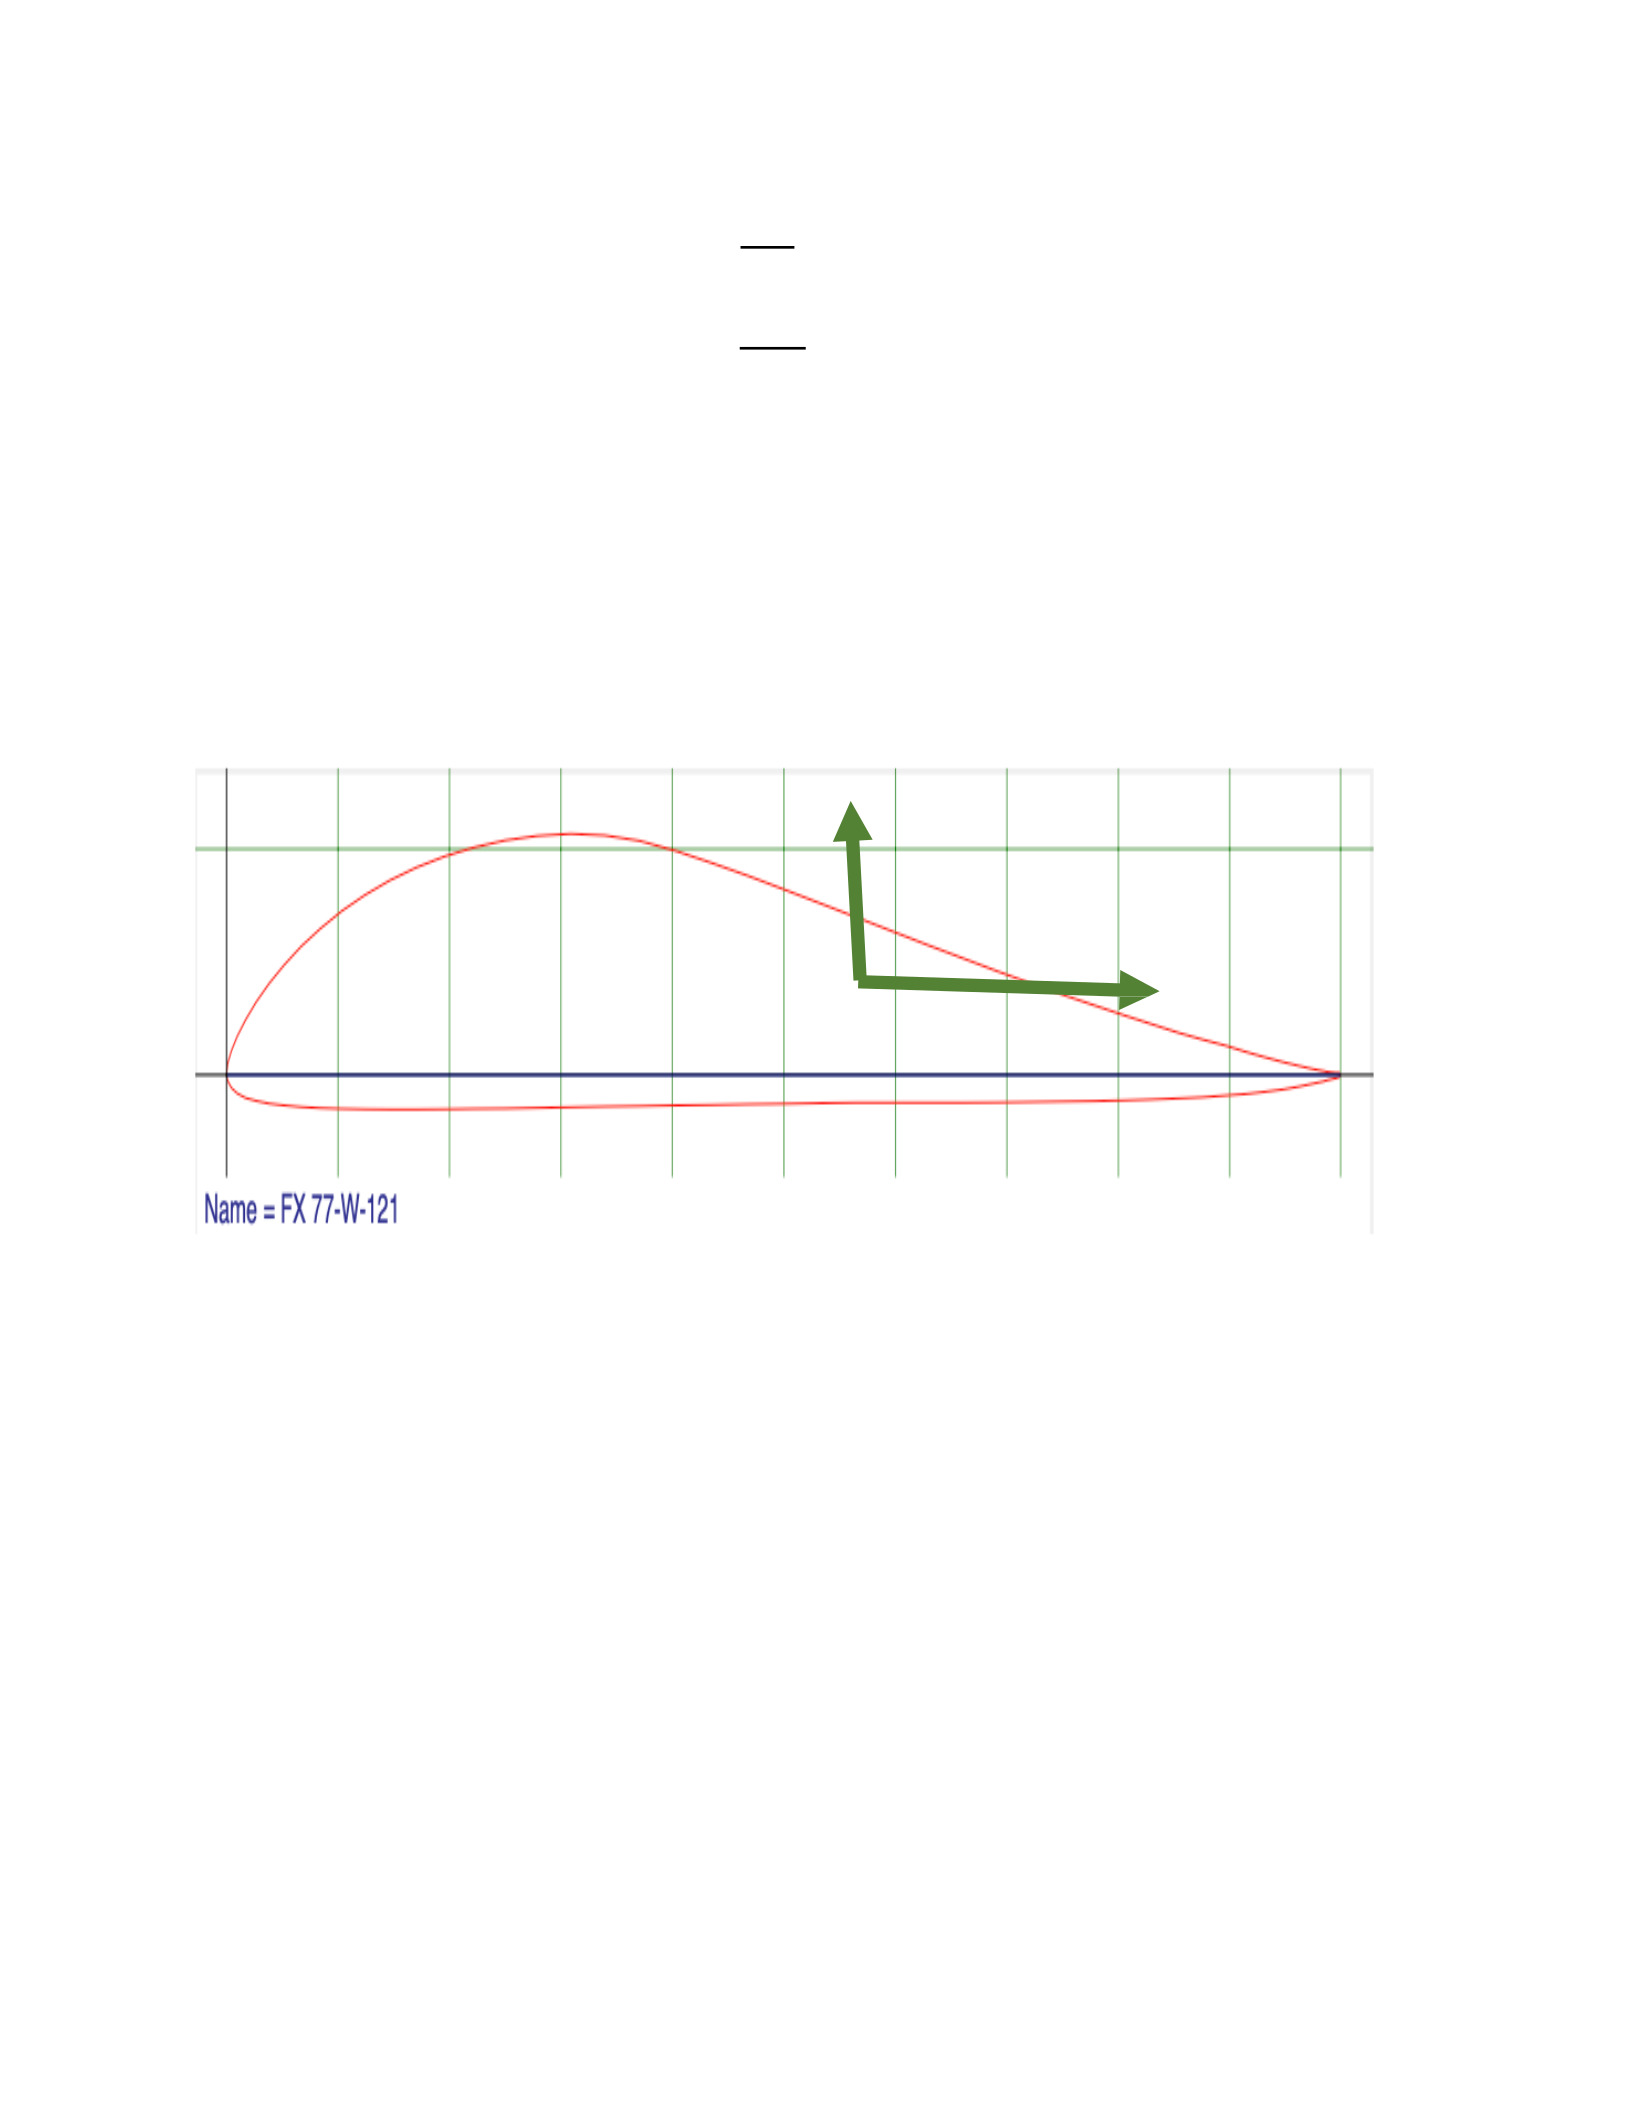
�
23
C =
𝐿
Question ∞
(2.5)
Where
L is the lifting
force, D is the
tensile force,
S is the reference area (Blade
area)
q
'
is dynamic pressure
.
C
D=𝐷
Qu
esti
on
∞
(2.6)
Figure 2.4
An
gka
t
Tari
k
24
Figure 2.5
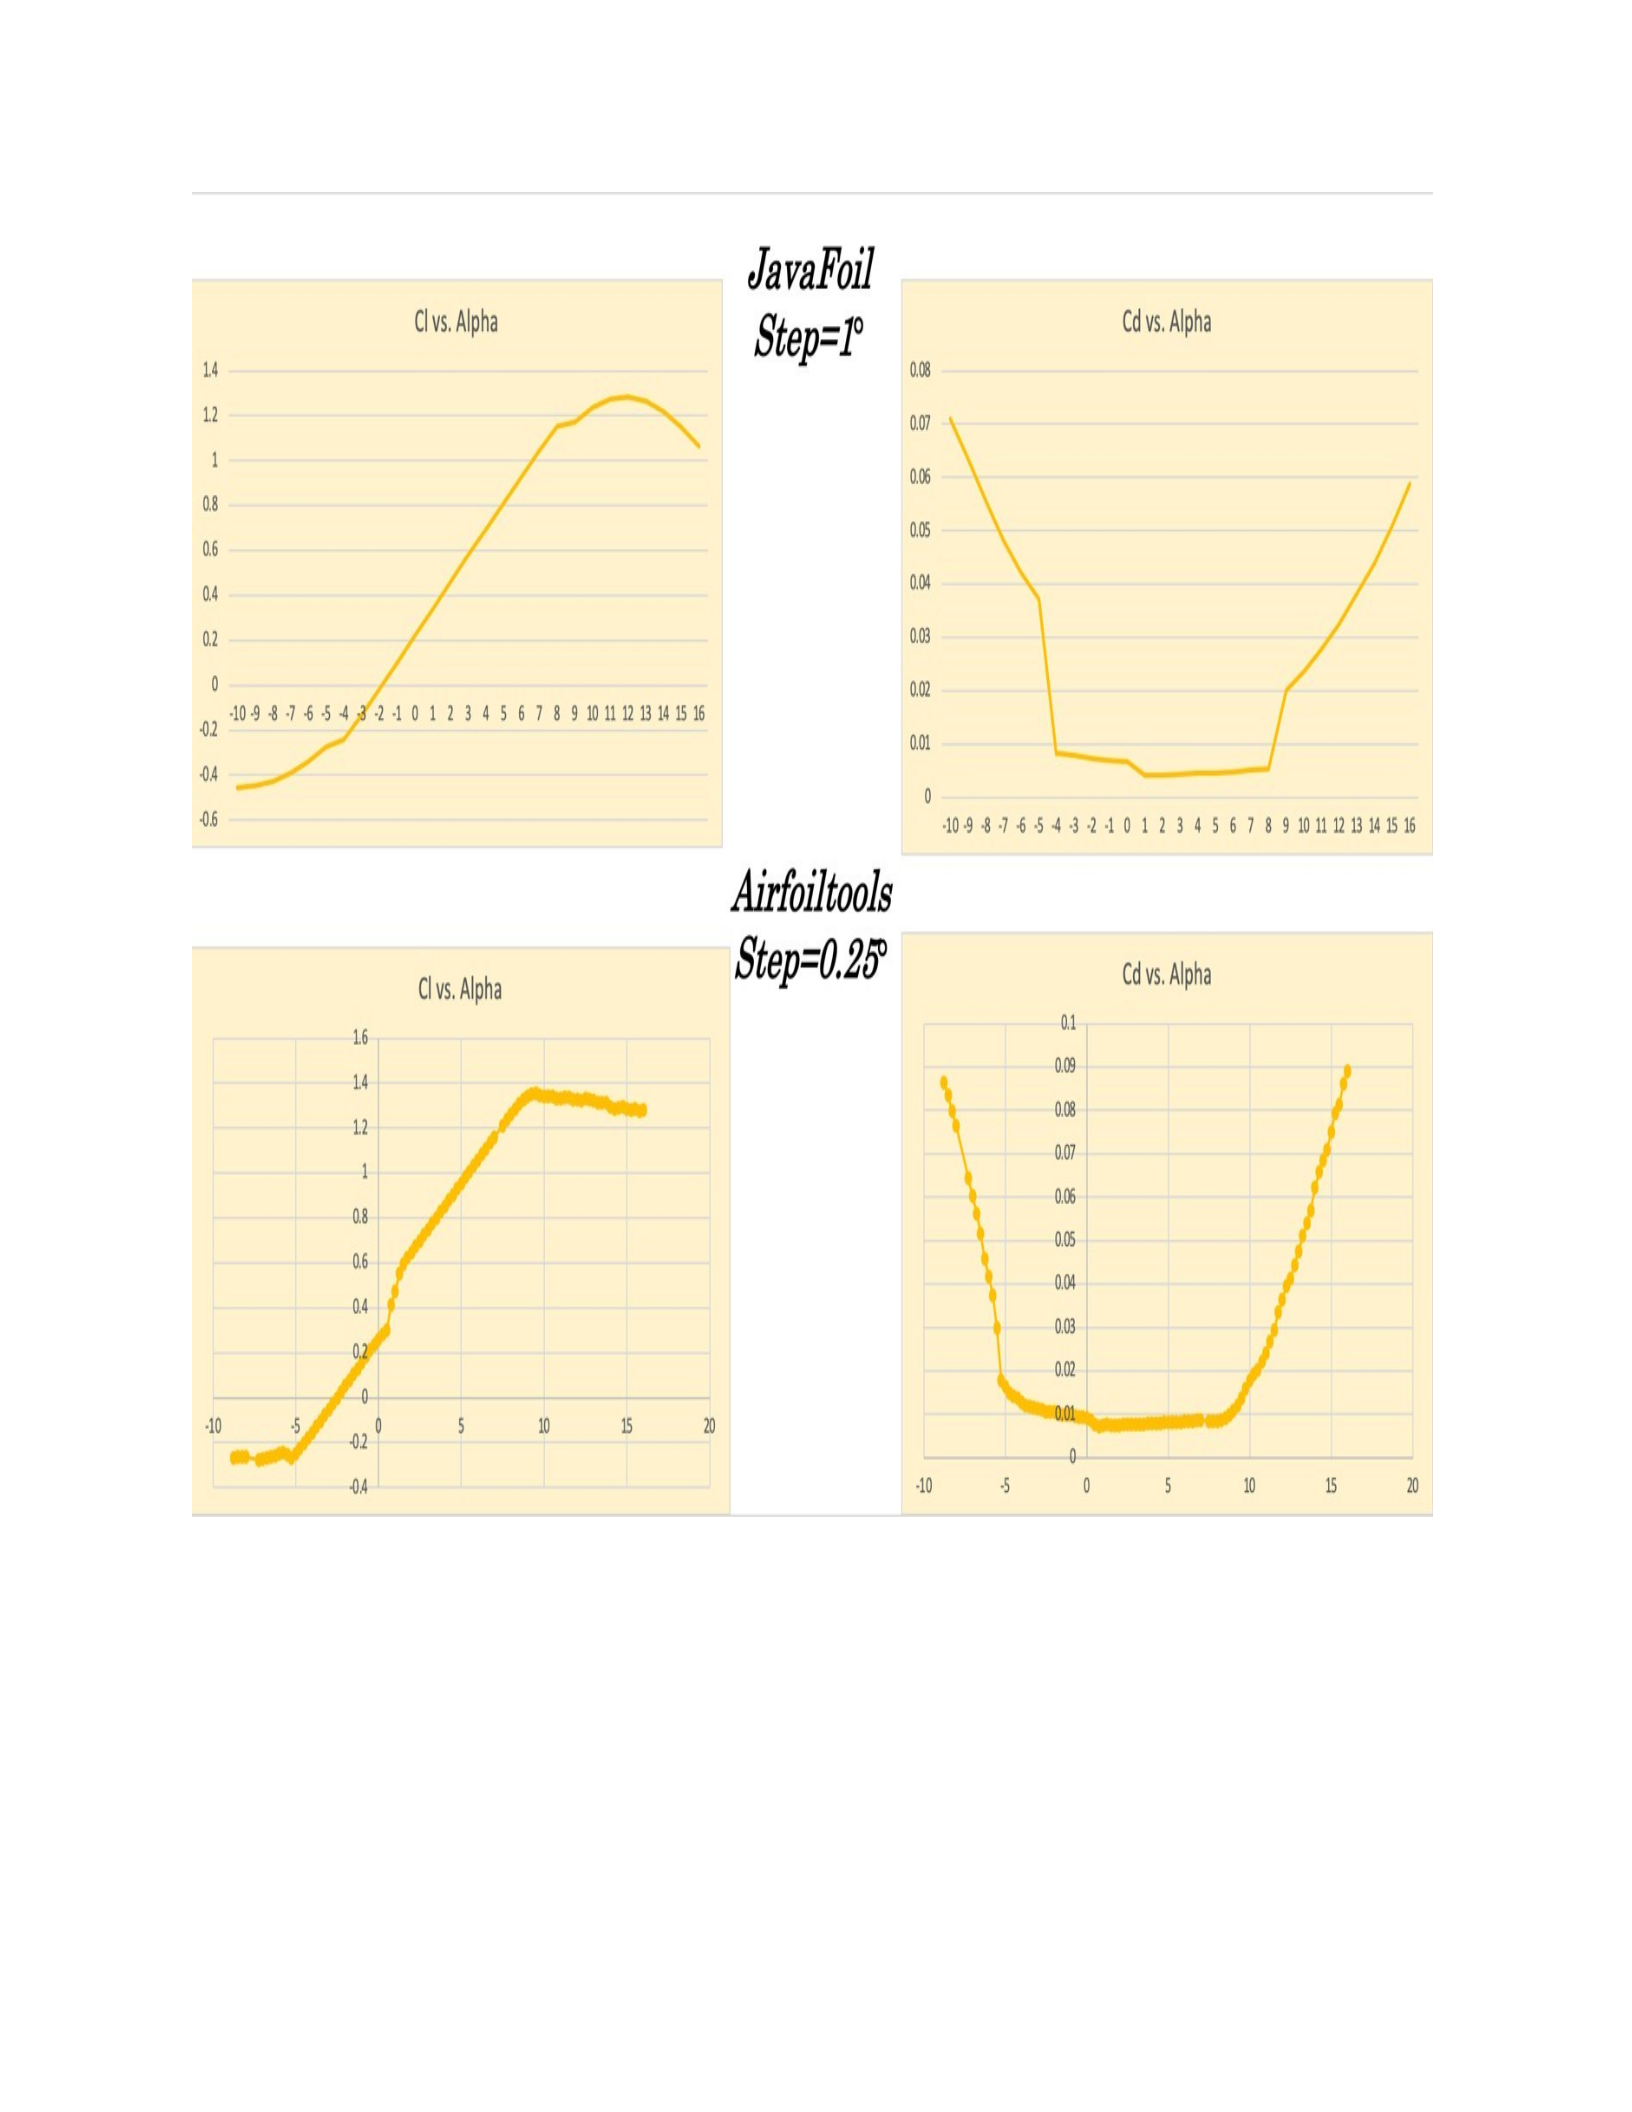
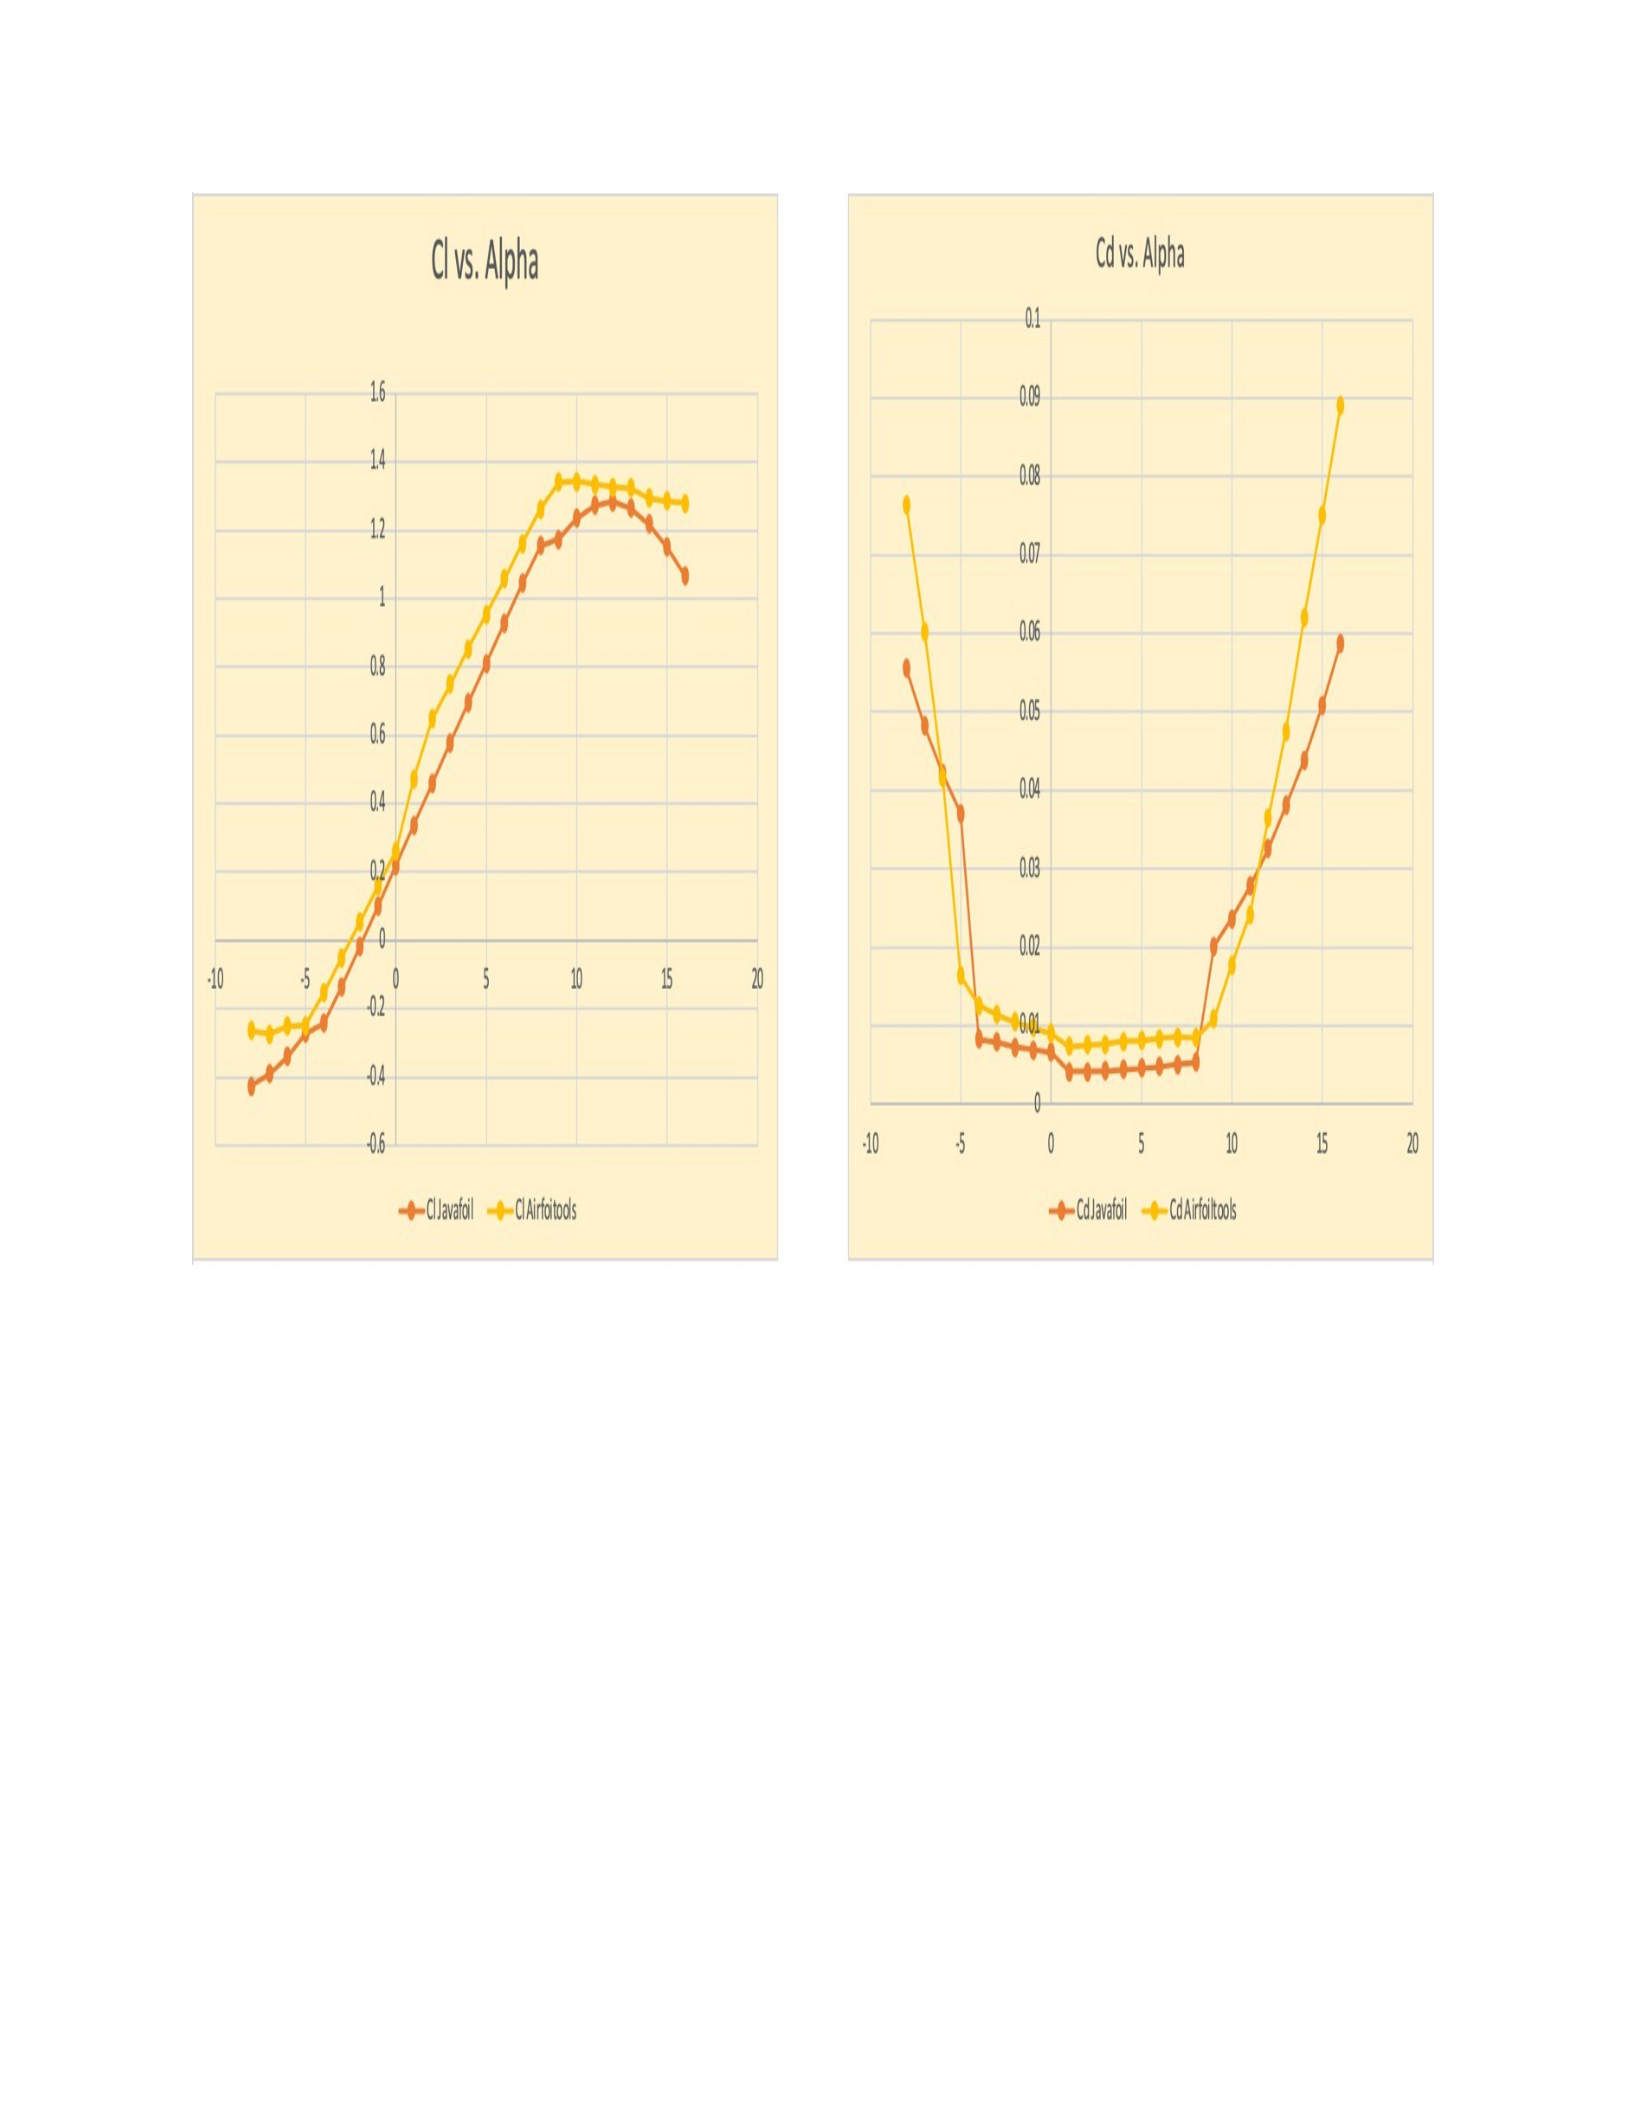
Figure 2.5 shows the change in the pull coefficient of the lift of the FX-77-W-121 airfoil when
the angle of attack is −10° ≤ α ≤16 when the angle of step is 1 degree. based on
Javafoil and Airfoiltools software. Their results support each other well.
25
Figure 2.6
Figure 2.6 shows the result of the drag ang loft coefficient of the FX-77-W-121 airfoil when the
angle of attack is −8° ≤ α ≤16 when the angle of step is 0.25 degrees in the same graph.
based on Javafoil and Airfoiltools software. Their results support each other well in these
conditions as well.
26
-15
cl (FX77-02349-01)
1.5
1
0.5
-1 0 -5 0
0 5 10 15
-0.5
-1
cd (FX77-02349-01)
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.7
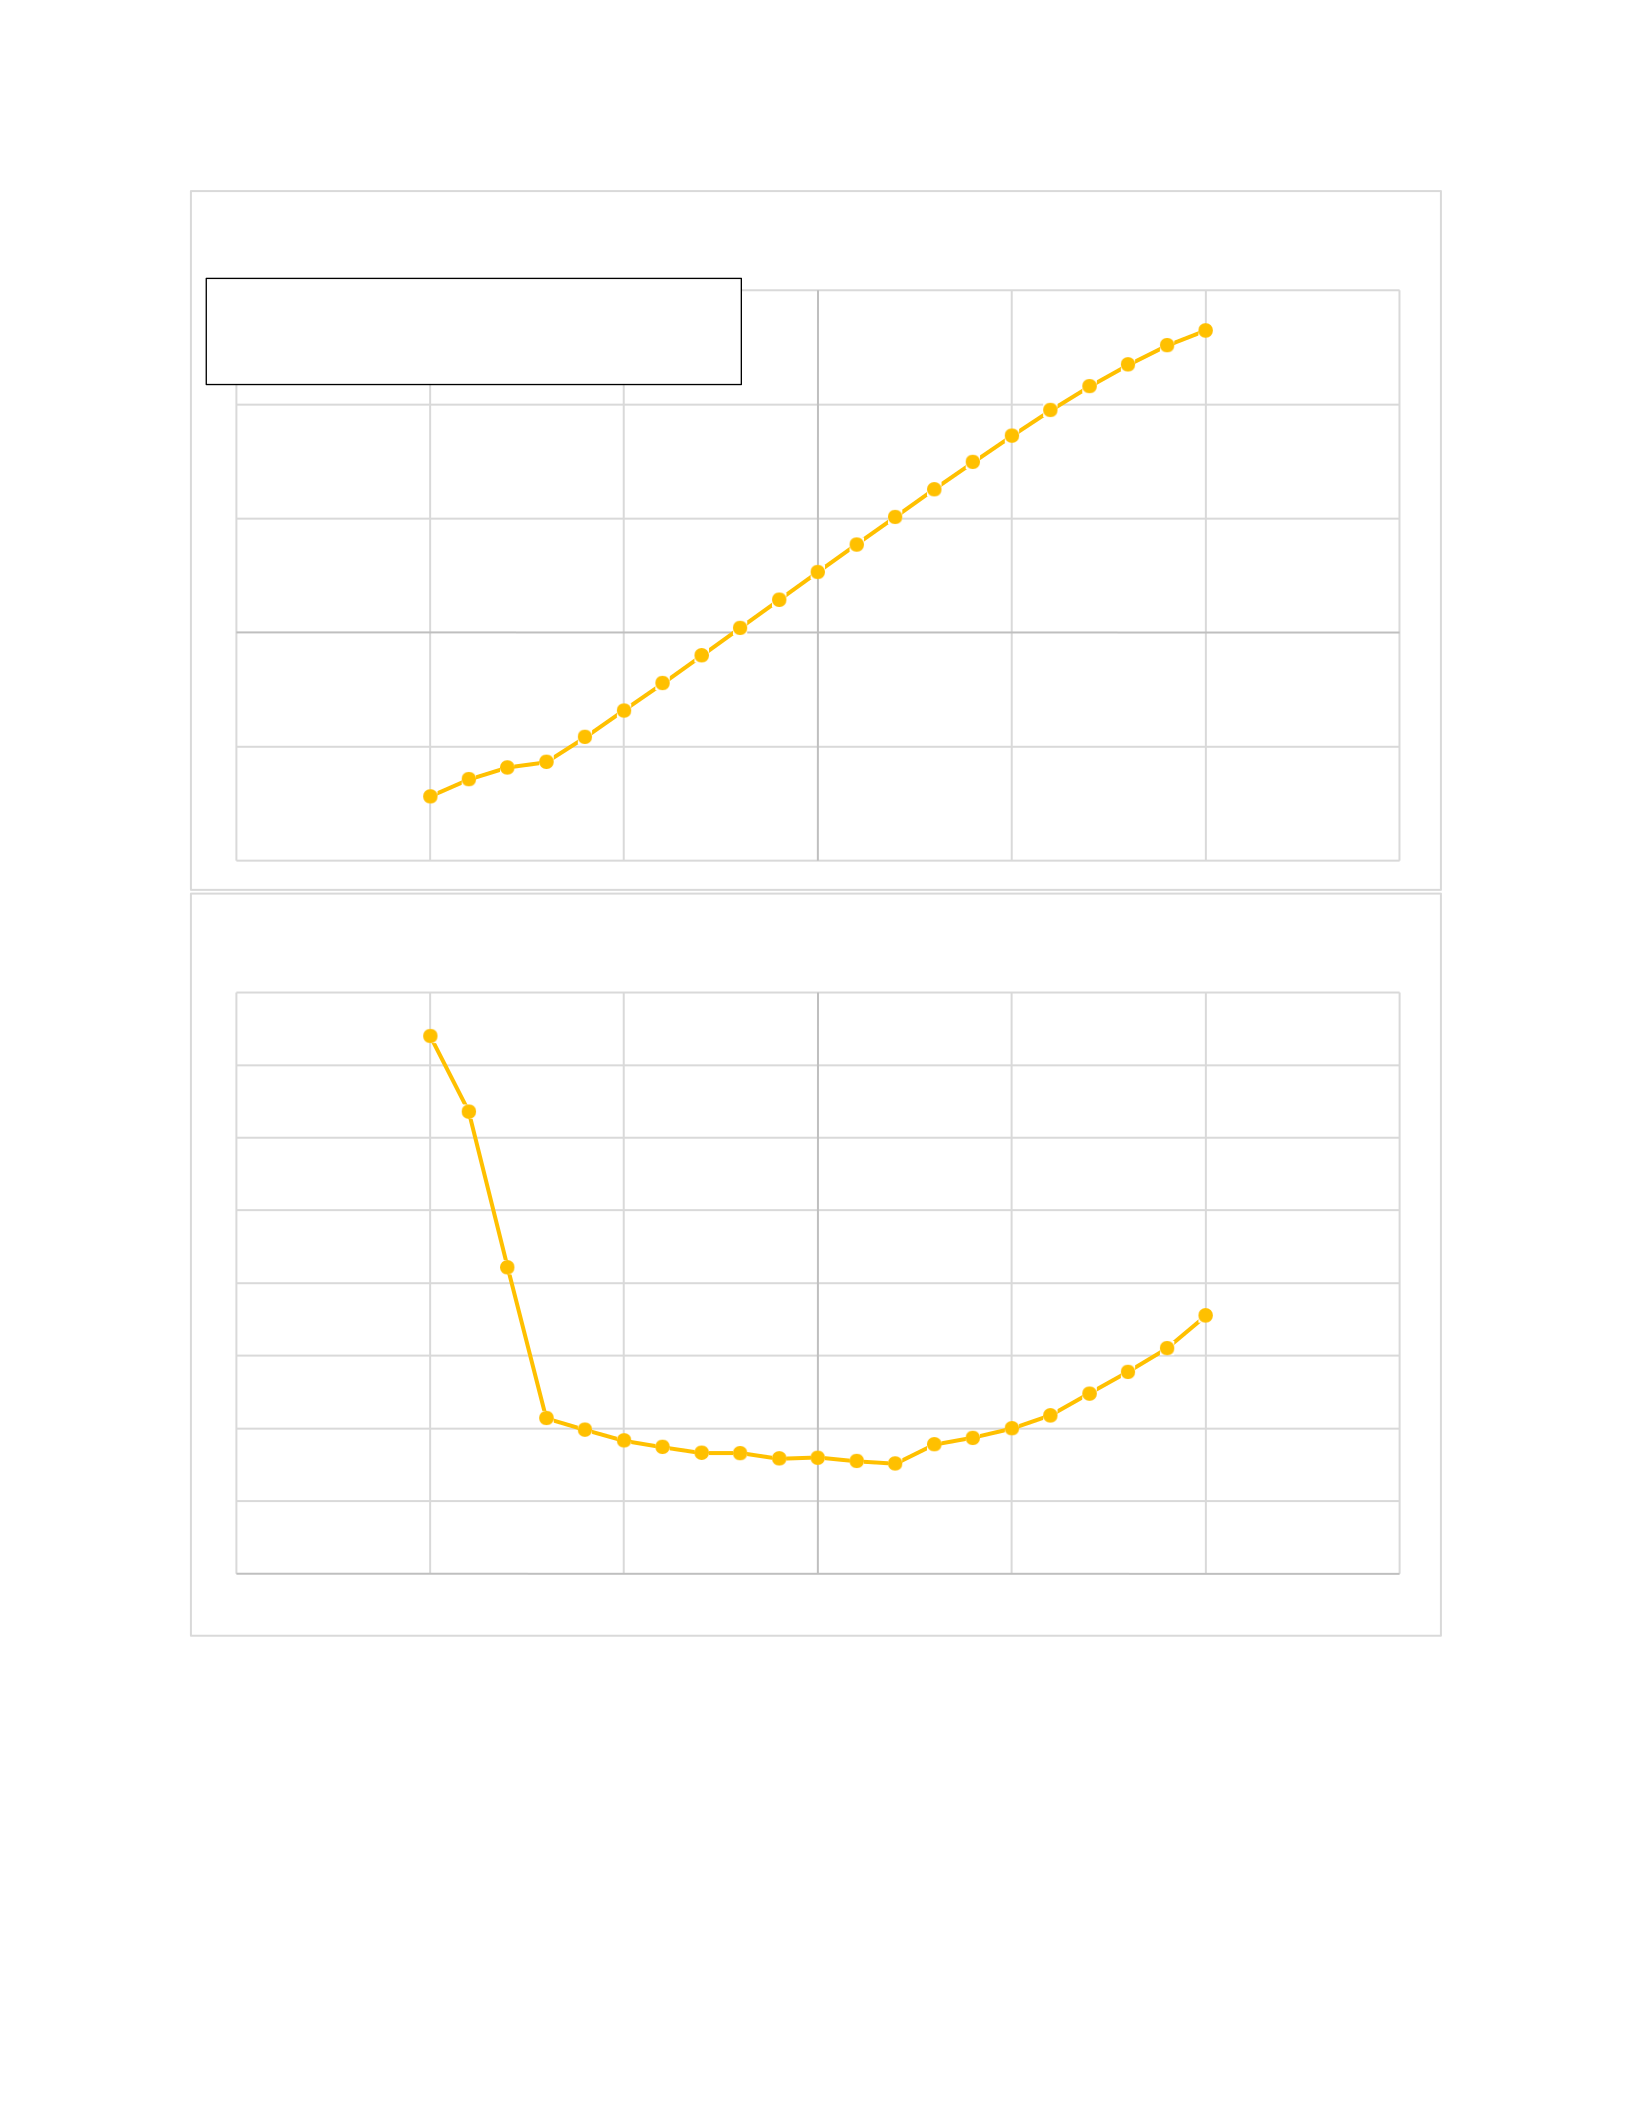
Figure 2.7 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the first airfoil of the X77-02349-01 blade.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
27
-15
cl (FX-02336-02)
2
1.5
1
0.5
-1 0 -5 0
0 5 10 15
-0.5
-1
cd (FX-02336-02)
0.1
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.8
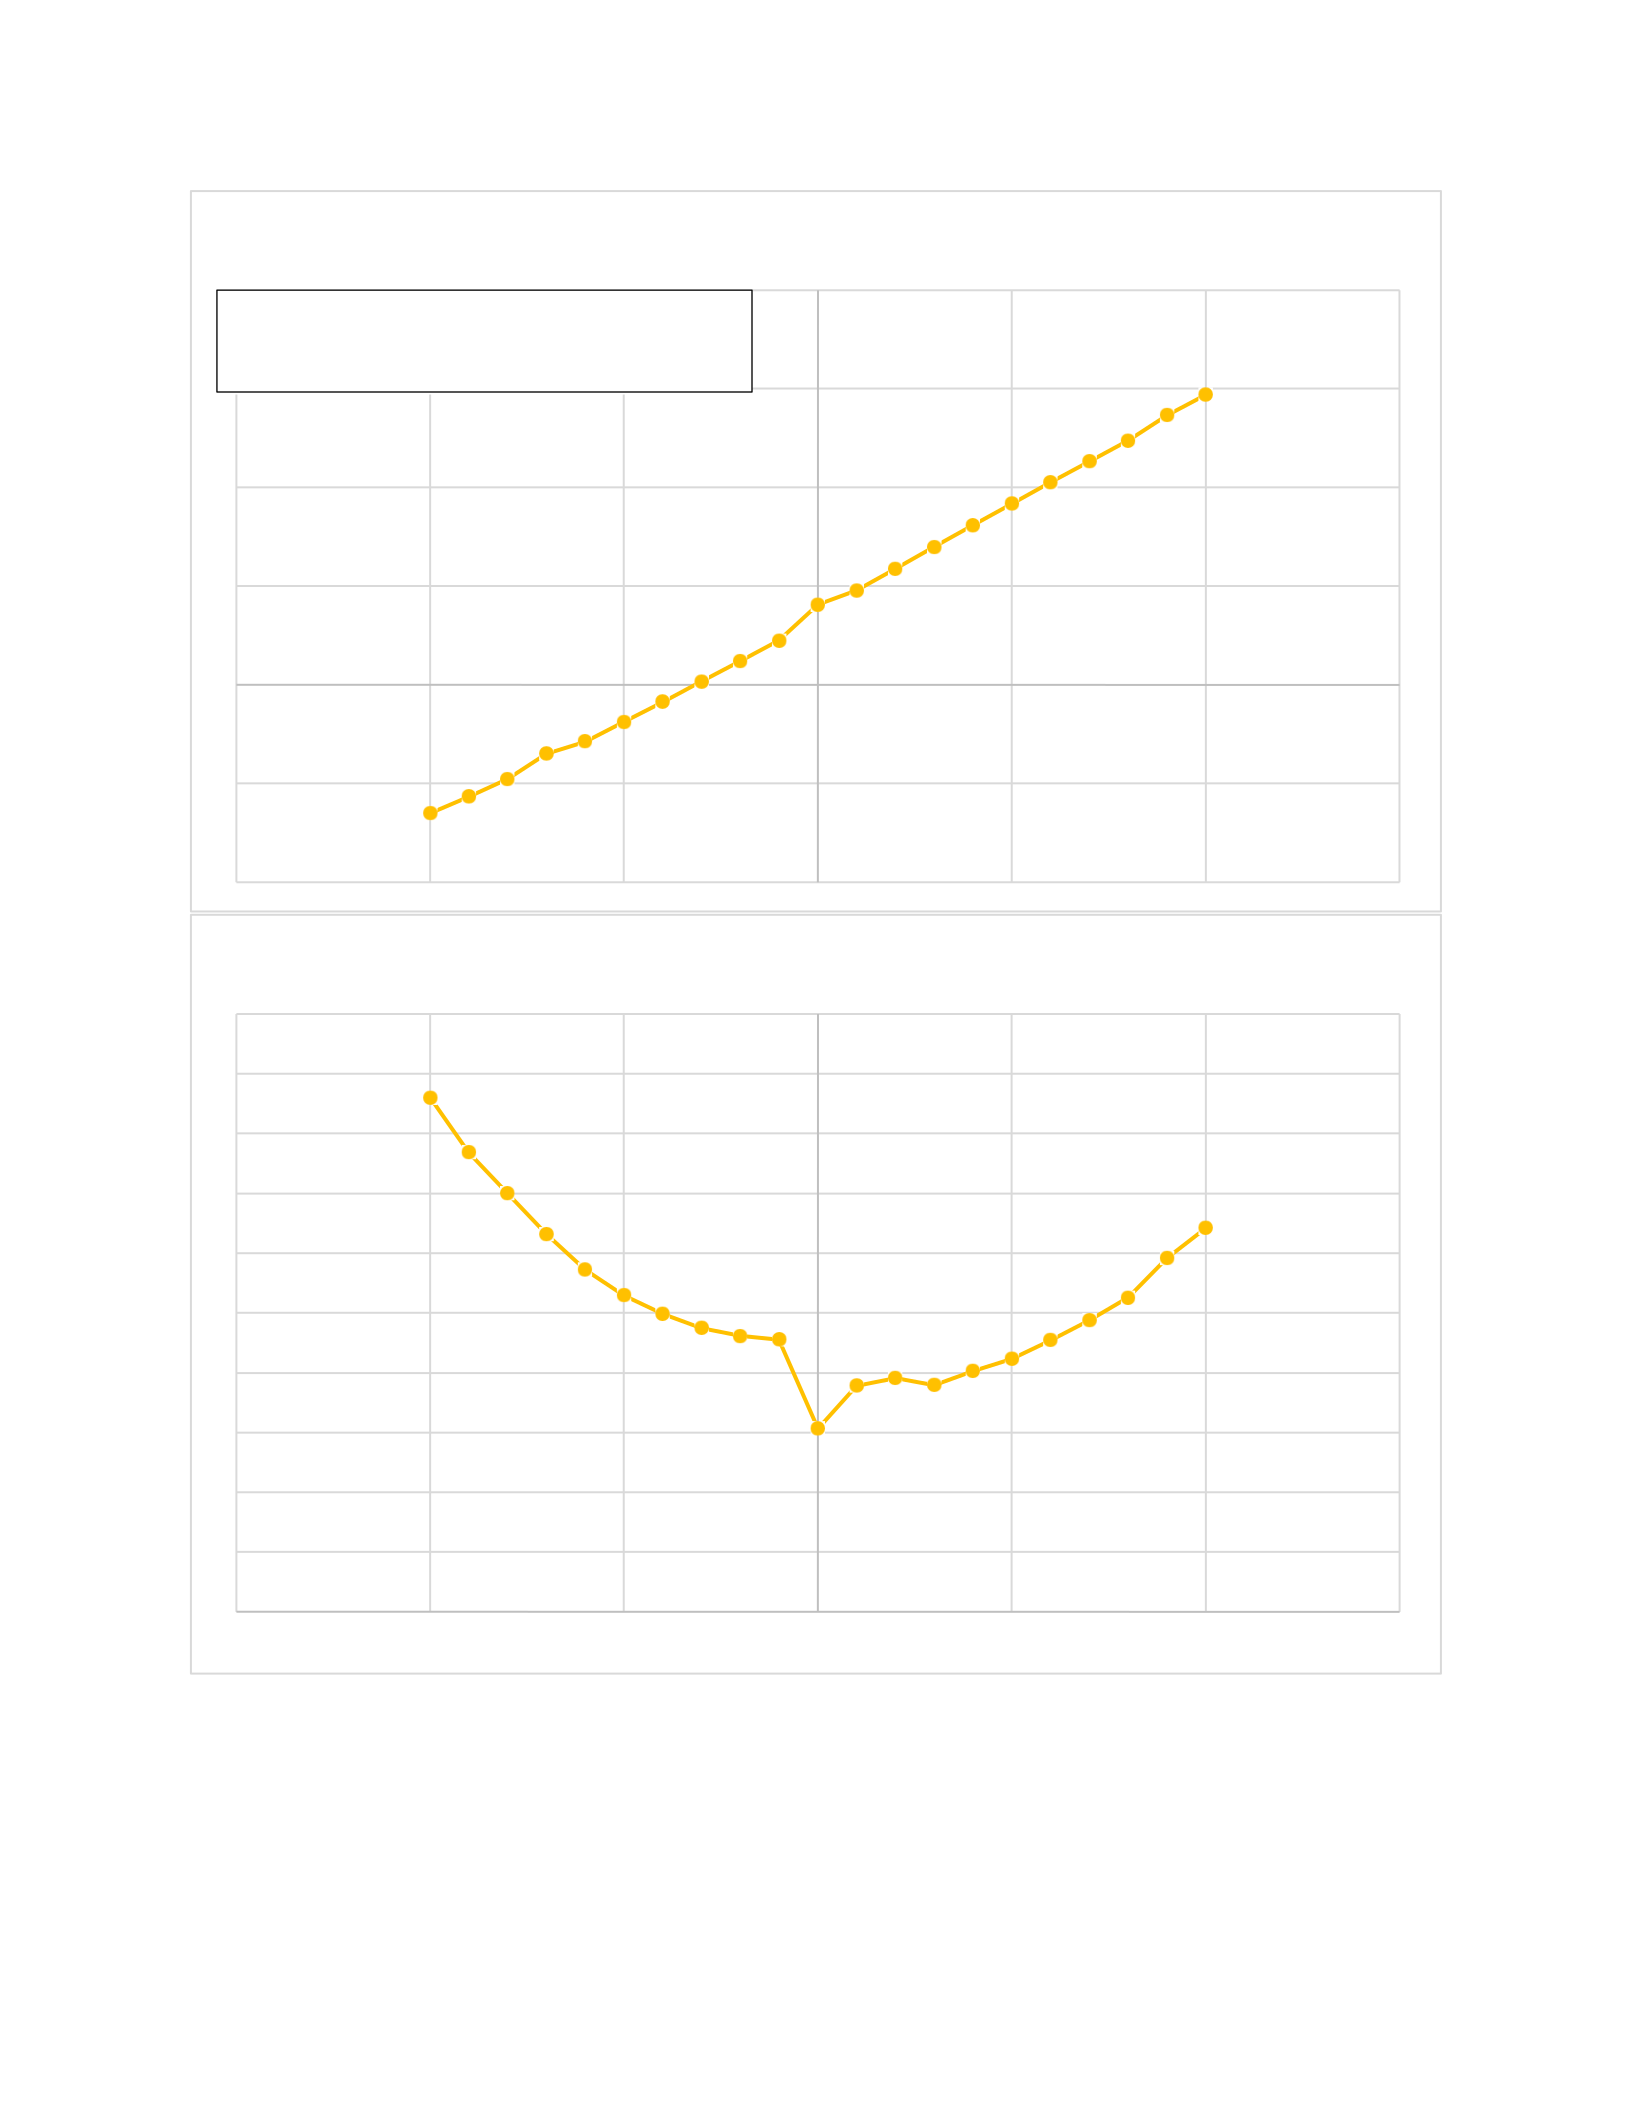
Figure 2.8 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the airfoils of the two blades X77-02336-02.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
28
-15
cl (FX77-02301-03)
2
1.5
1
0.5
-1 0 -5 0
0 5 10 15
-0.5
-1
cd (FX77-02301-03)
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.9
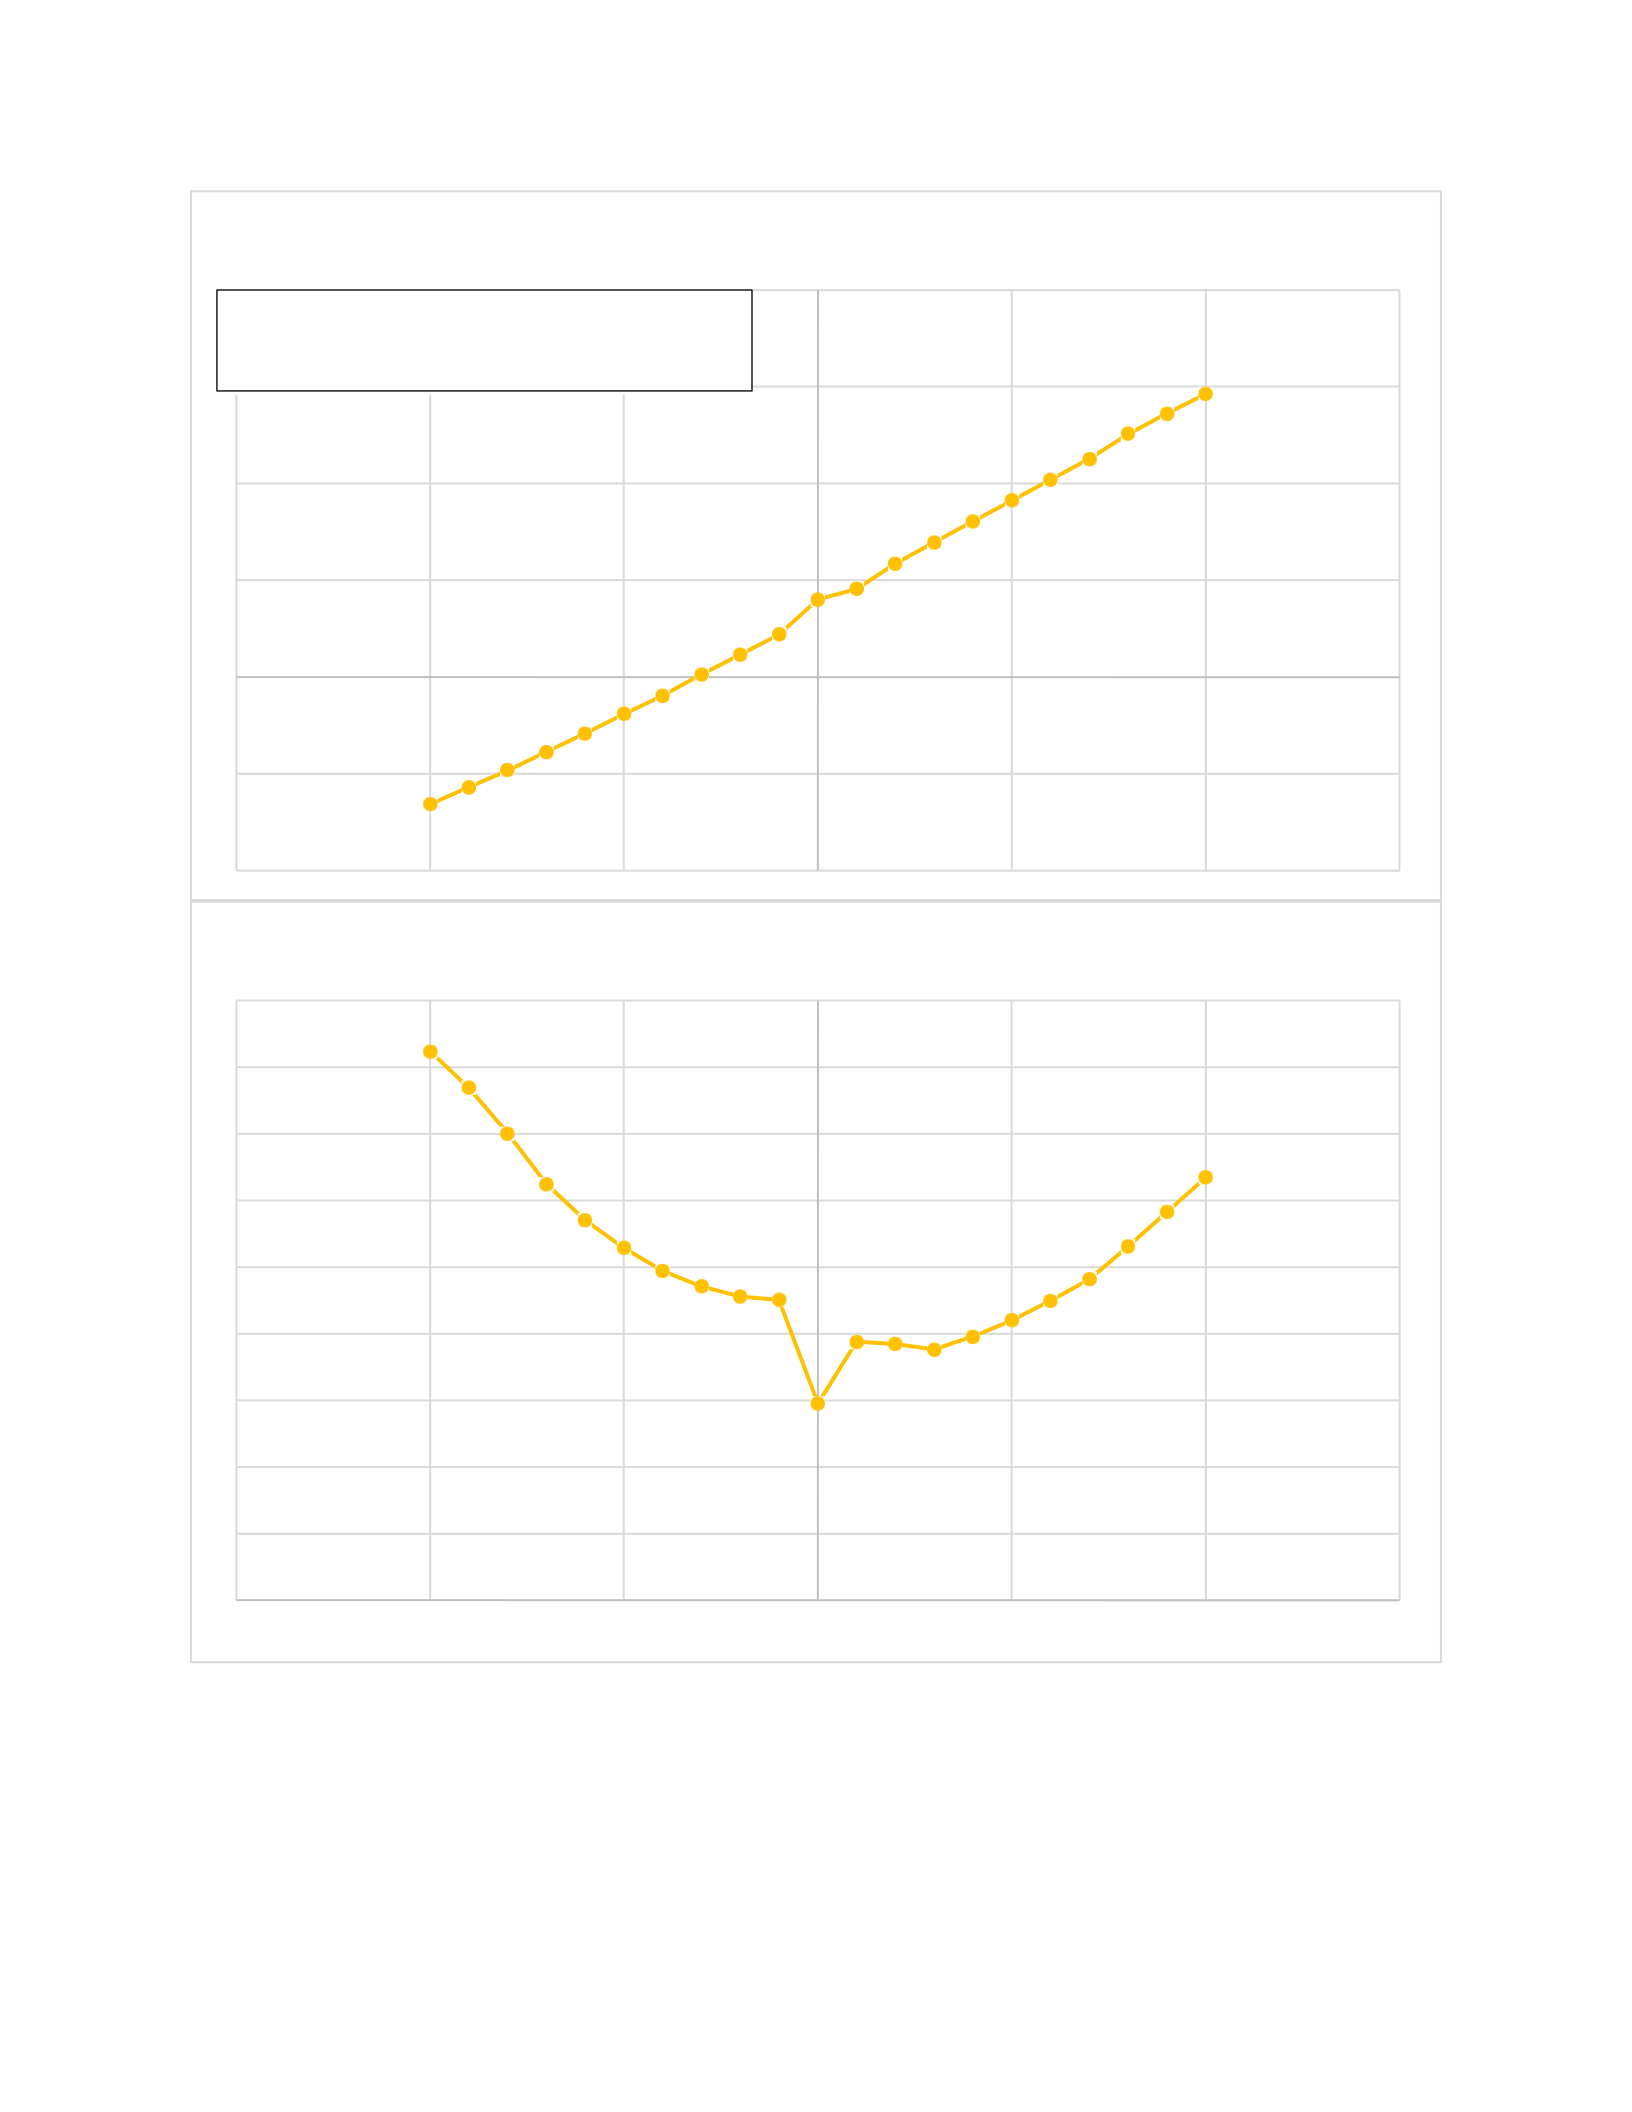
Figure 2.9 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the X77-02301-03 blade's third blade airfoil.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
29
Figure 2.10
Figure 2.10 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the X77-02237-04 blade airfoil.
cl (FX77-02237-
04)
2
1.5
1
0.5
0
-1 0 -5 0 5 10 15
-0.5
-1
cd (FX77-02237-
04)
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
-15
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
30
-15
cl (FX77-02223-05)
2
1.5
1
0.5
-1 0 -5 0
0 5 10 15
-0.5
-1
cd (FX77-02223-05)
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.11
Figure 2.11 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the X77-02223-05 blade's fifth blade airfoil.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
31
-15
cl (FX77-02162-06)
2
1.5
1
0.5
-1 0 -5 0
0 5 10 15
-0.5
-1
cd (FX77-02162-06)
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.12
Figure 2.12 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the six-blade airfoil X77-02162-06.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
32
-15
cl (FX77-02092-07)
2
1.5
1
0.5
-1 0 -5 0
0 5 10 15
-0.5
-1
cd (FX77-02092-07)
0.1
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.13
Figure 2.13 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the seven-blade airfoil X77-02092-07.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
-15
33
cl (FX77-02012-08)
1.5
-1 0 -5 0 5 10 15
-0.5
-1
cd (FX77-02012-08)
0.1
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.14
Figure 2.14 shows the Lift and Pull Coefficient vs. Attack angle (−10° ≤ α ≤ 10°) of the
X77-02012-08 eight-blade airfoil.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
1
0.5
0
34
-15
cl (FX77-01925-09)
1.5
1
0.5
-1 0 -5 0
0 5 10 15
-0.5
-1
cd (FX77-01925-09)
0.1
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.15
Figure 2.15 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the X77-01925-09 blade's ninth blade airfoil.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
35
-15
cl (FX77-01832-10)
1.5
1
0.5
-1 0 -5 0
0 5 10 15
-0.5
-1
cd (FX77-01832-10)
0.1
0.09
0.08
0.07
0.06
0.05
0.04
0.03
0.02
0.01
0
-15 -10 -5 0 5 10 15
Figure 2.16
Figure 2.16 shows the Lift and Resistance Coefficients vs. Attack angle (−10° ≤ α ≤ 10°) of
the ten-blade airfoil X77-01832-10.
X-Axis: Attack Angle
Y-axis: Lift and Drag Coefficients
36
Figures 2.7 to 2.16 show how the lift and drag coefficients change in relation to the first ten
airfoils listed in table 2.1 for different attack angles −10° ≤ α ≤ 10° . Since all airfoils are
from the same airfoil family (FX-77-W), we see similar behavior in their lift and drag
coefficients.
Figure 2.17 Lift Coefficient vs. AOA
Finally, Figure 2.17 shows the lift coefficient results for the 25 different airfoils listed in Table
2.1 when the angle of attack is zero. This result is created by Javafoil software.
37
Figure 2.18 Drag Coefficient vs. AOA
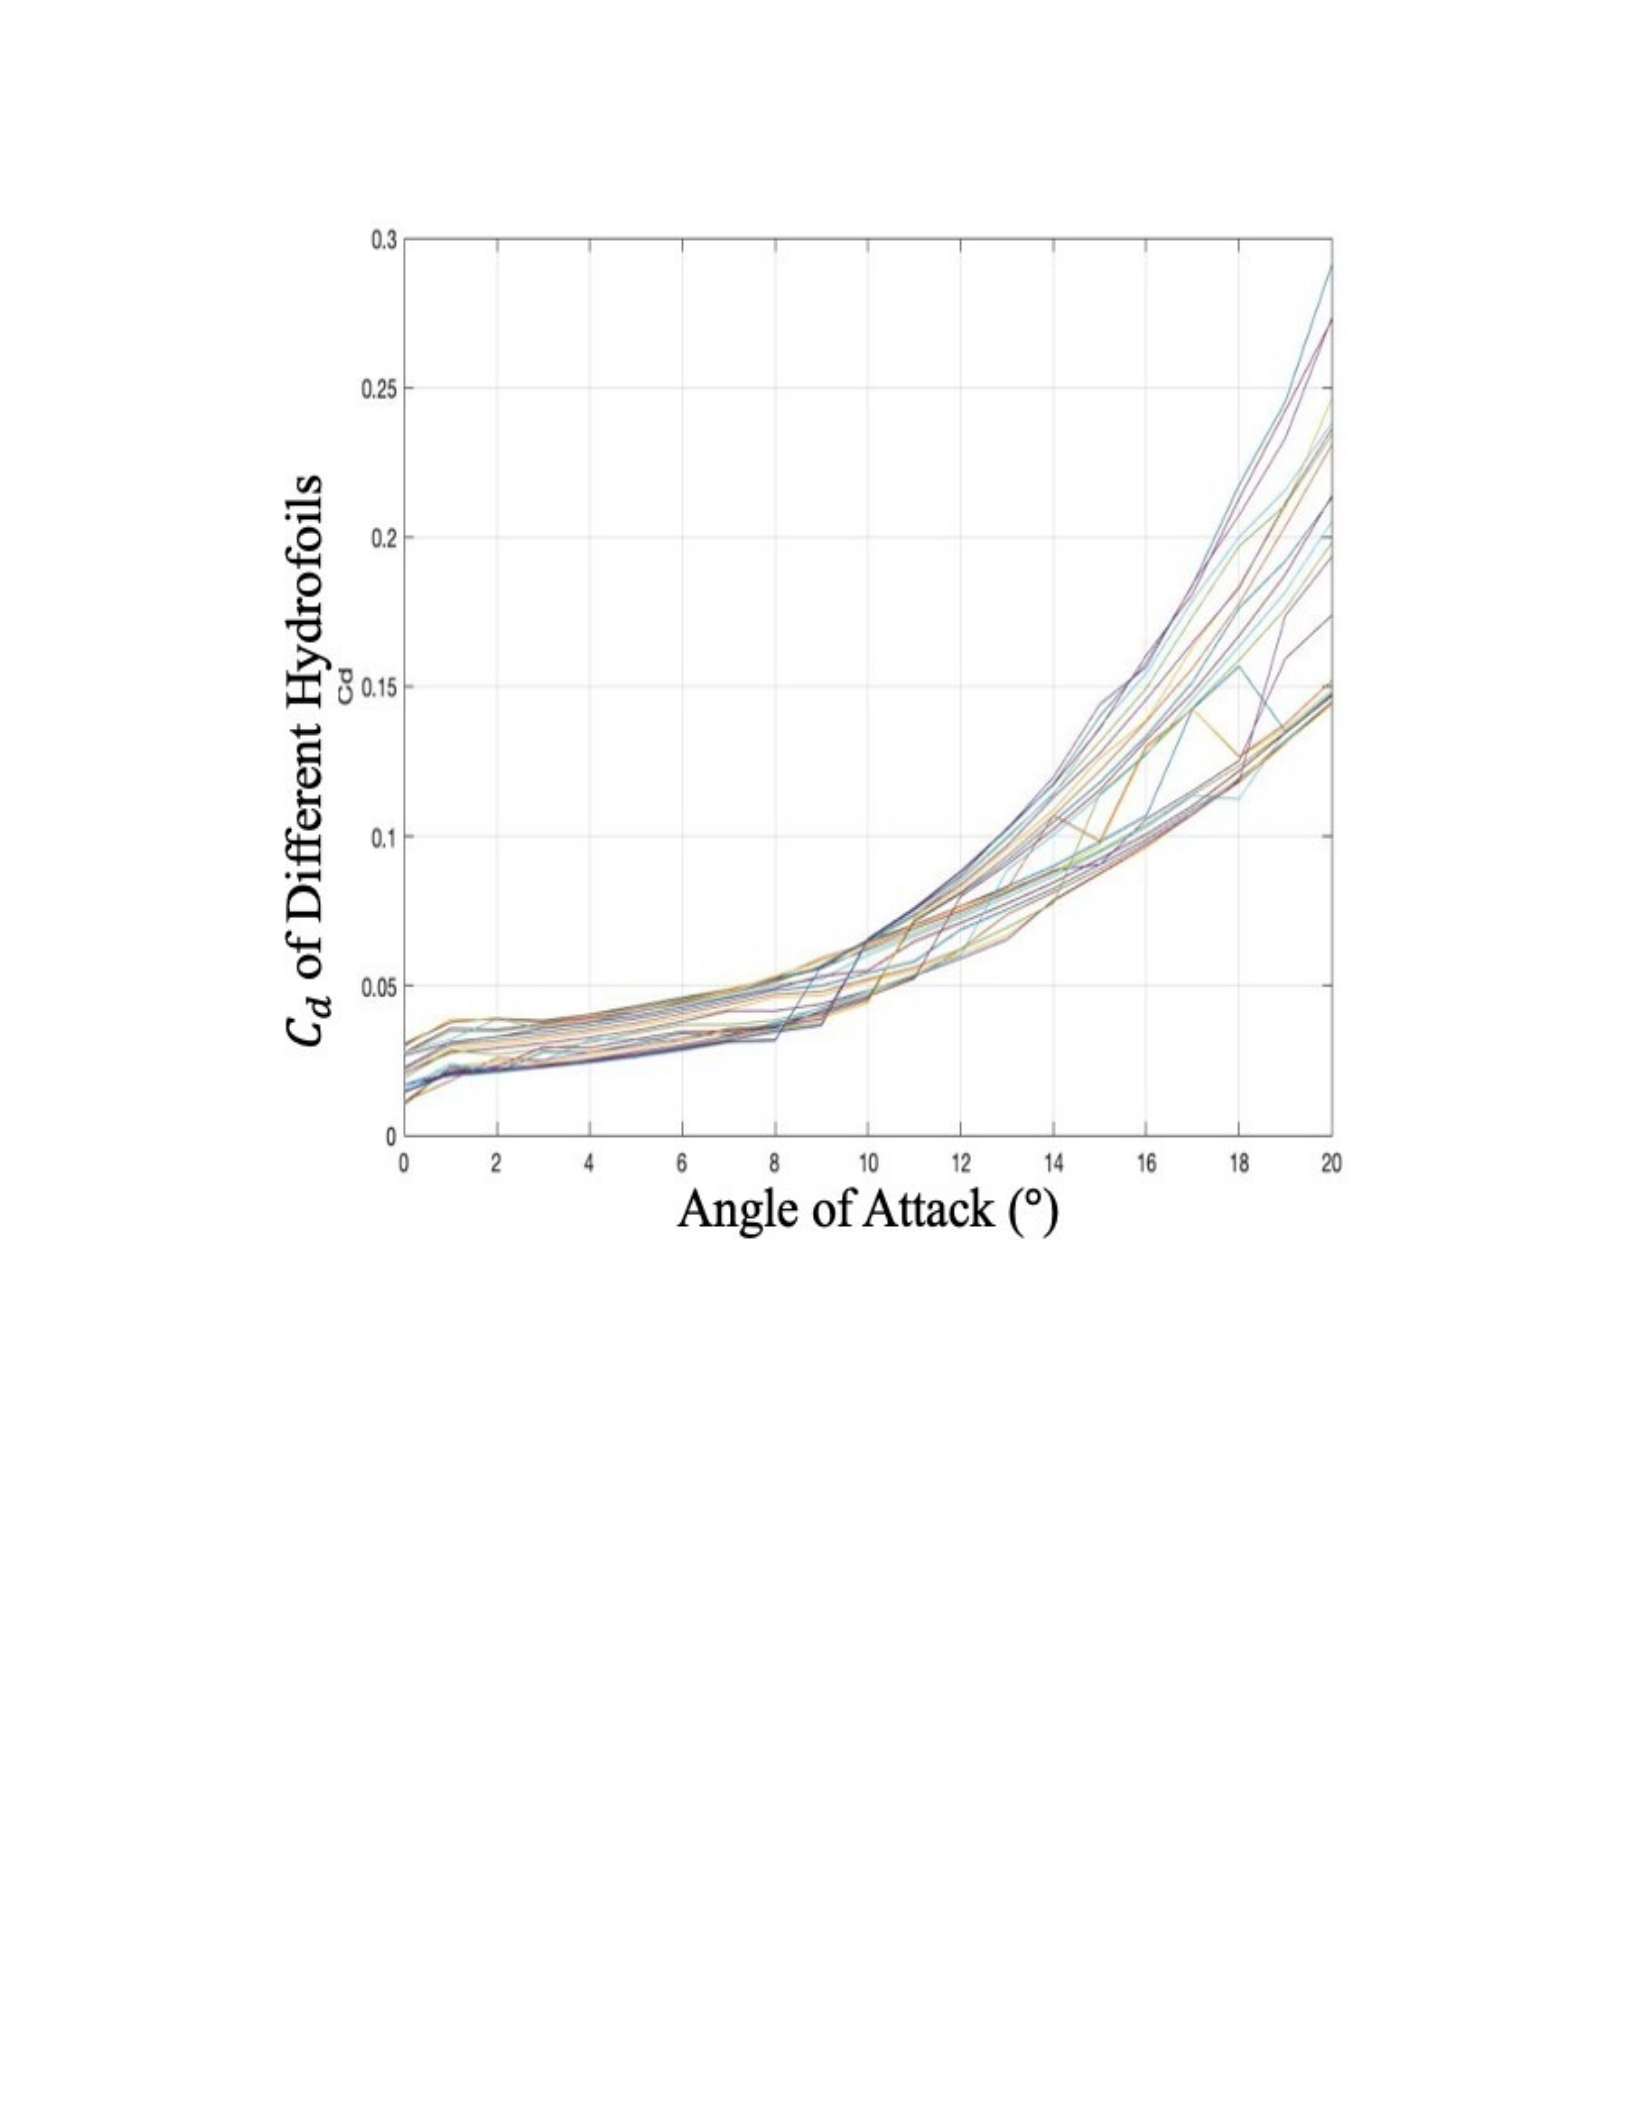
Figure 2.18 illustrates the drag coefficient results for 25 different airfoils listed in
Table 2.1 when the angle of attack is zero. This result is created by Javafoil
software.

38
Chapter 3: Designing the propeller, Selecting materials and 3D printing
results
International Towing Tank Conference (ITTC) as the main reference: https://ittc.info
The International Tortoise Tank Conference (ITTC) stands as a globally renowned
organization that plays a crucial role in advancing the field of hydrodynamics and maritime
engineering.
Founded in 1933, ITTC serves as a collaborative platform for researchers, engineers, and
professionals from around the world, bringing together expertise in the study of ship
hydrodynamics, propulsors, and other related fields. The main objective of ITTC is to promote
international cooperation and facilitate the exchange of knowledge and advances in tow tank
testing methodologies.
At the core of ITTC's mission is the establishment and maintenance of universally accepted
standards for hydrodynamic testing in towing tanks. This standard, often referred to as the
"ITTC Recommended Procedure," provides a comprehensive set of guidelines and protocols for
conducting experiments in tow tanks. By establishing these standard procedures, ITTC ensures
consistency and comparison of results obtained from various towing tank facilities around the
world. This harmonization is essential for accurate assessment of ship and propulsor
performance, as well as for the validation of numerical simulations and computational models.
The ITTC is governed by member states, and its organizational structure includes technical
committees that focus on specific aspects of hydrodynamic research. The committee covers a
broad spectrum of topics, including resistance and propulsion, marine maintenance, model
testing, and instrumentation. Experts from member states actively contribute to the work of this
committee, sharing insights, discussing challenges, and proposing progress on the ground.
One of the flagship events organized by ITTC is the International Towing Tank Conference
itself which is held every three years. The conference serves as a liaison for the global tug-of-
war tank community, providing a platform for researchers to present their latest findings,
discuss emerging trends, and engage in fruitful collaborations. These conferences typically
feature a variety of technical sessions, workshops, and plenary lectures delivered by leading
experts in the field. Participants include researchers, academics, industry professionals, and
students, fostering a dynamic environment for the exchange of ideas and the exploration of
innovative solutions to hydrodynamic challenges.
ITTC has been instrumental in driving advances in tow tank technology and testing
methodologies. As hydrodynamic research has evolved over the years, ITTC has adapted to
incorporate new technologies and methodologies, ensuring its relevance in the rapidly changing
landscape of maritime engineering. The organization encourages the integration of cutting-edge
techniques, such as Computational Fluid Dynamics (CFD), into the realm of tow tank testing,
promoting a holistic approach to hydrodynamic research.

39
In addition, ITTC actively contributes to the education and training of professionals in its field.
Through its publications, conferences, and collaborative initiatives, the organization
disseminates knowledge, best practices, and the latest developments in hydrodynamics. This
role of education is crucial for fostering a skilled workforce and encouraging innovation in the
maritime industry.
In conclusion, the International Tank Towing Conference (ITTC) stands as a cornerstone in the
field of hydrodynamics, providing a collaborative platform for the international towing tank
community. Through its commitment to standardization, research collaboration, and knowledge
dissemination, ITTC plays a critical role in advancing our understanding of ship hydrodynamics
and propulsor performance. The triennial conference and ongoing work of the ITTC technical
committee contribute to the continuous evolution of the tow tank testing methodology, ensuring
its relevance and effectiveness in addressing contemporary challenges in maritime engineering.
3.1 Designing the propeller
Designing blades with varied airfoil profiles is a challenging task that requires an
in-depth understanding of aerodynamics, structural mechanics, and optimization
techniques. SolidWorks can serve as a powerful tool to help in this process, but
successful design also relies on good engineering principles, thorough analysis,
and physical testing to ensure the blade meets its intended purpose. Here are
a step-by-step procedure guide on how to design such a knife using SolidWorks:
I. Define Requirements: Clearly define the requirements and specifications
for your variable geometry bar. Consider factors such as desired lift,
resistance, material selection, blade length, rotation speed, and
application (e.g., wind turbines, aircraft propellers, or fans).
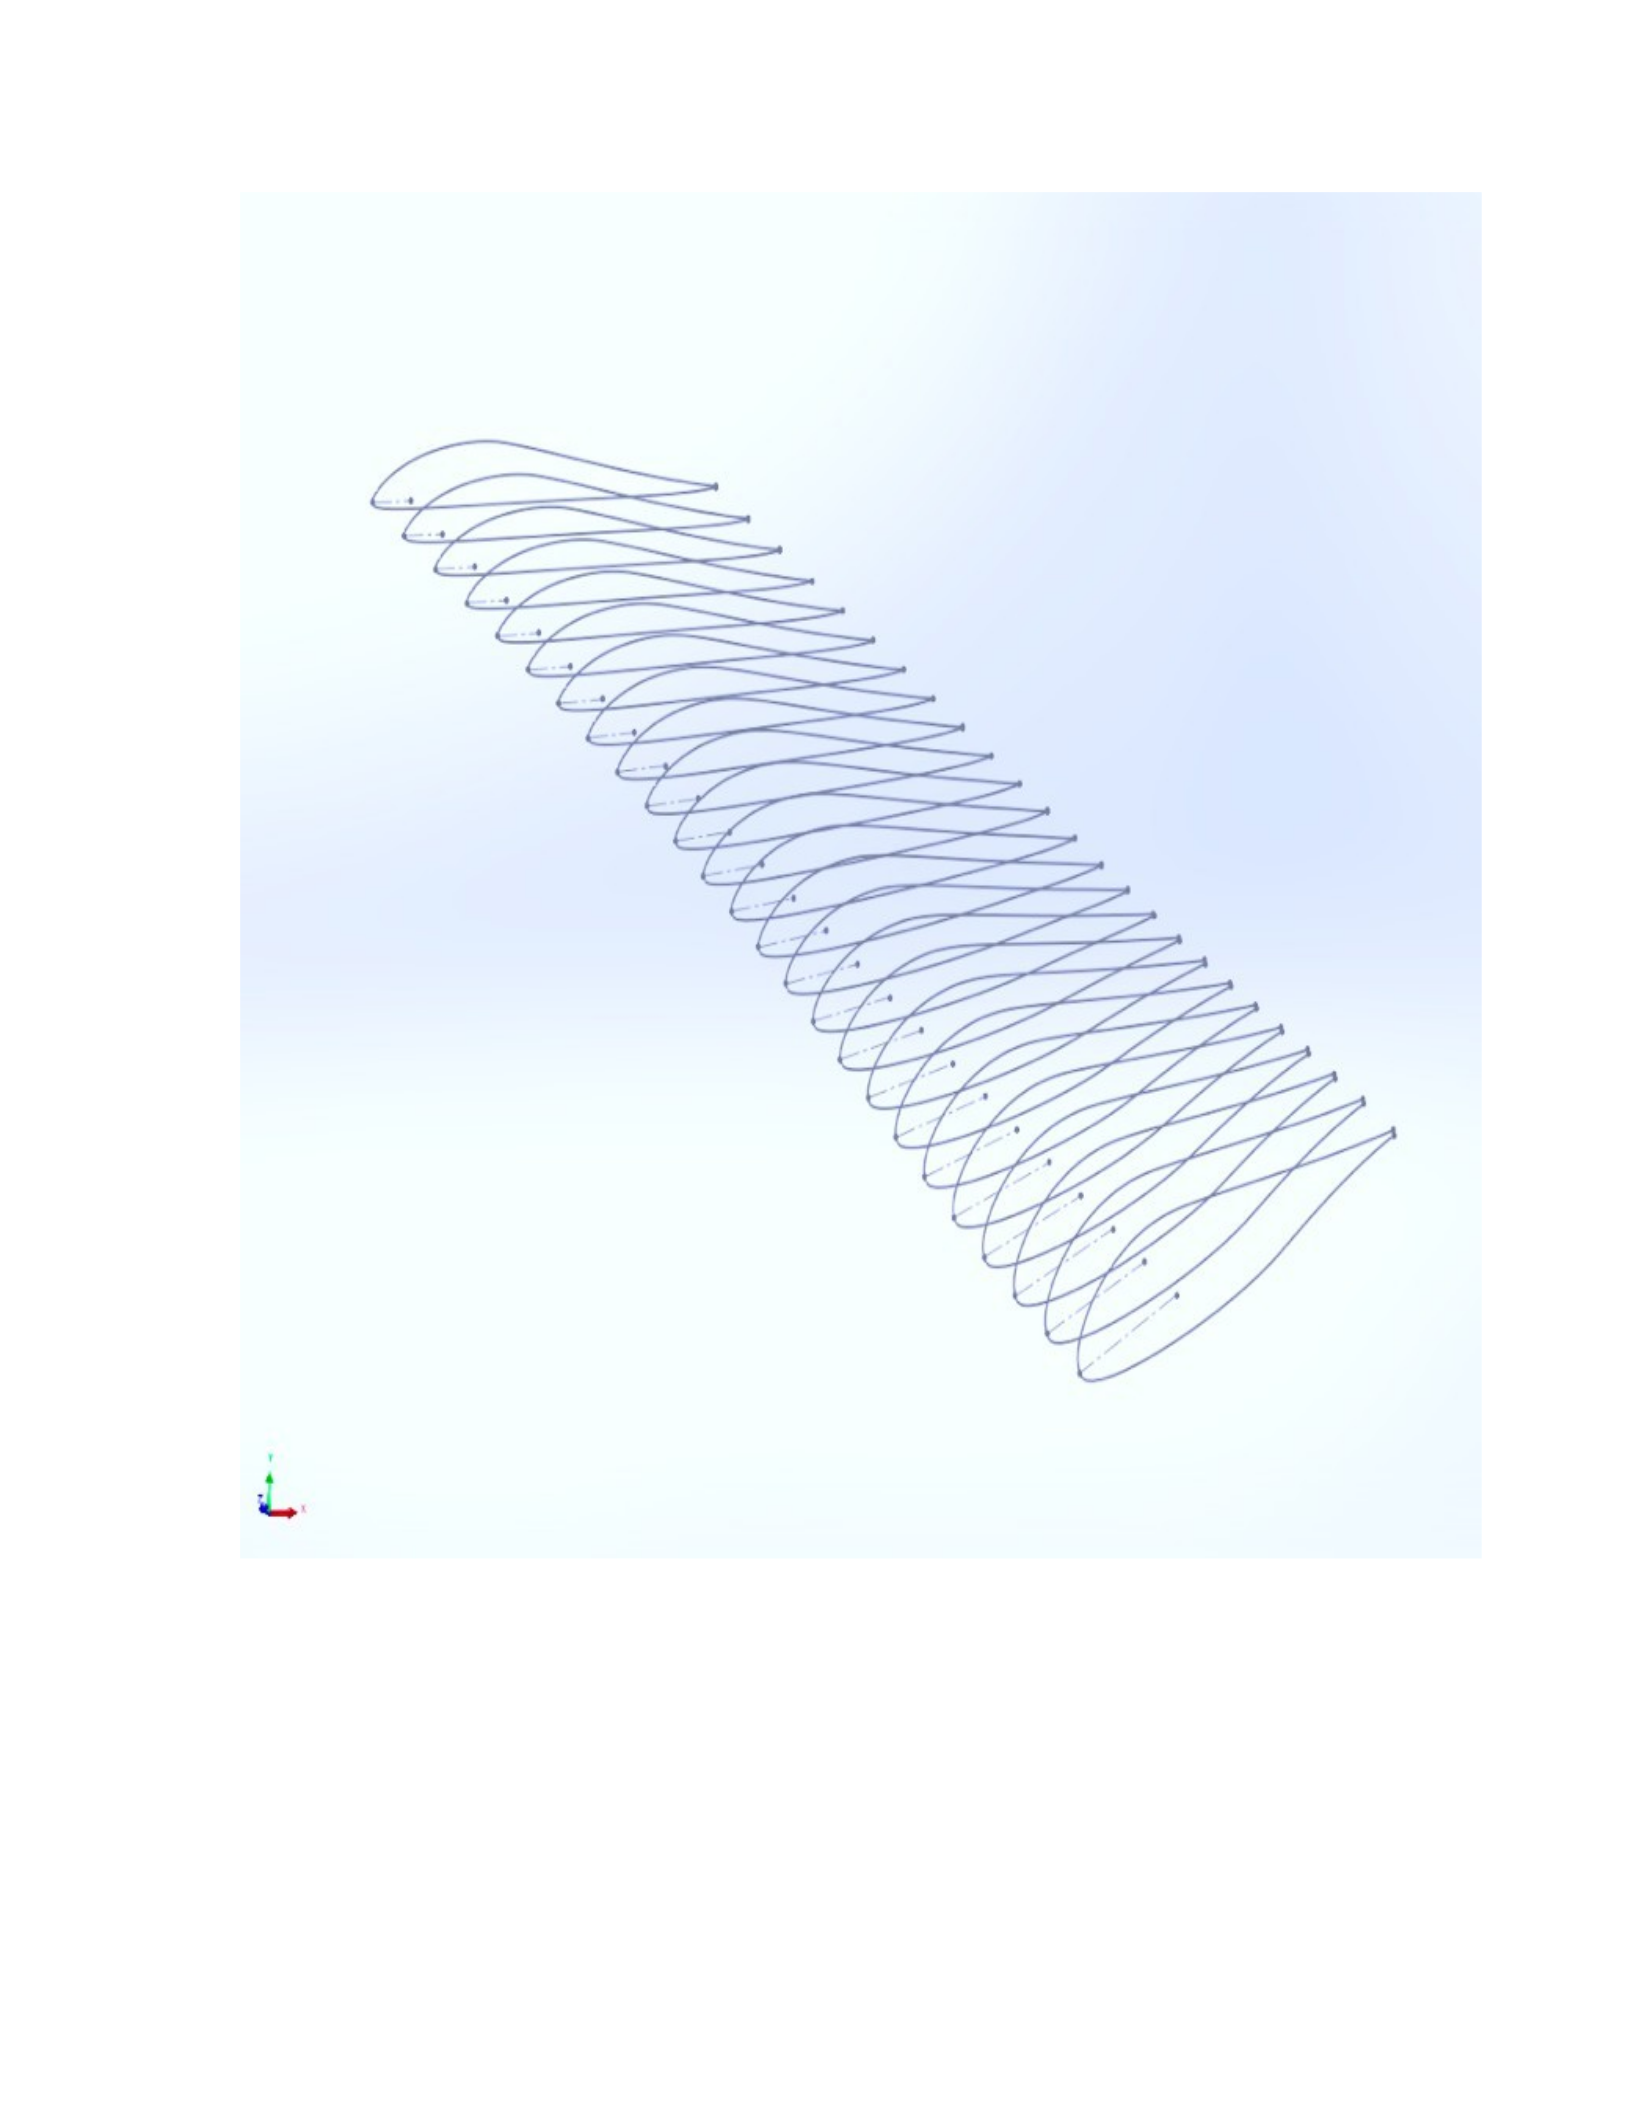
II. Importing Airfoil Profile Data and Sketching each airfoil: Select the
airfoil profile (By specifying a database for each airfoil that shows each
airfoil point in XYZ coordinates, in this case, we have 25 different
database points) to be used along the blade. These airfoil profiles should
be imported into Solidworks based on performance objectives, orders,
and specific conditions in each blade section. Then, by creating
individual fields for each foil, we can start sketching different profiles.
40
Figure 3.1 HYDROFOILS EXTRACTED FROM THEIR RESPECTIVE FIELDS.
41
III. Defining the Blade Path: we need to Define the path or trajectory that the
blade will follow. These paths can be straight, curved, or have any other
desired shape. We must ensure that the path is compatible with the
length and curvature requirements of your knife.
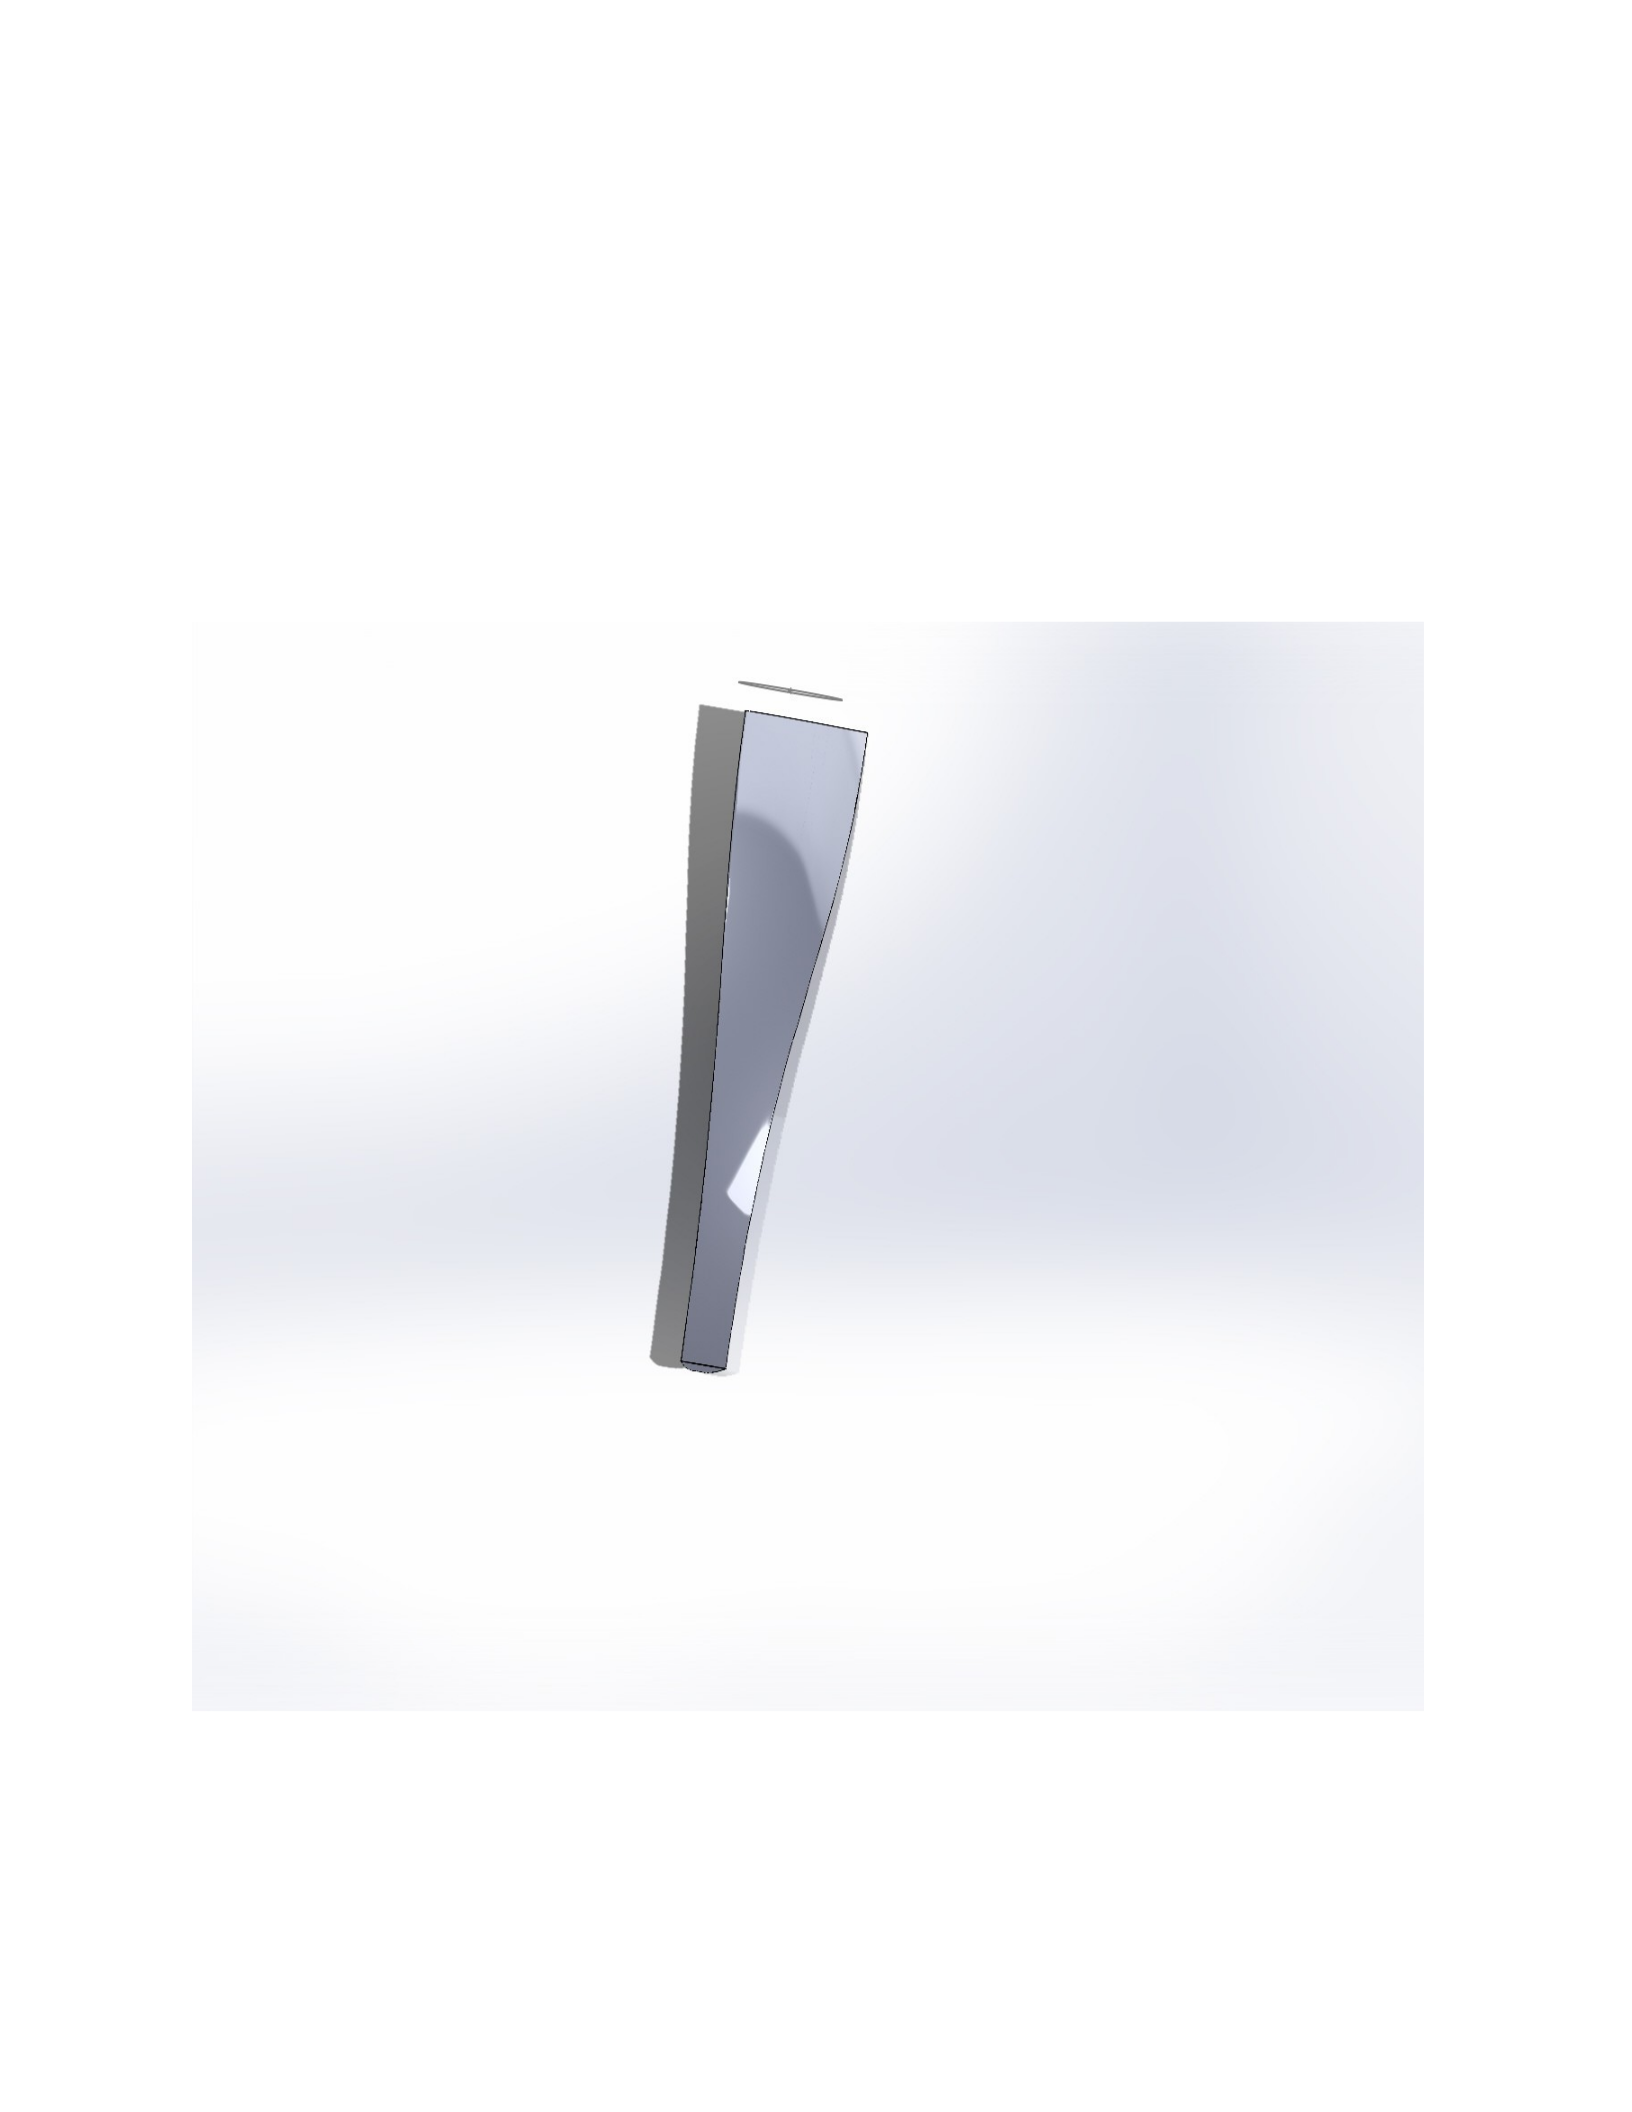
IV. Using the Loft Feature: The SolidWorks loft feature is used to create a
seamless transition between different parts of the airfoil. Lofting will
create a 3D blade shape by interpolating between the 2D sketches along a
defined path.
Figure 3.2: Blade shape after applying the Loft Feature
42
V. Adjusting Parameters: Change the geometry of the 3D blade as needed.
You may need to adjust the position and orientation of the sketch along
the path to achieve the desired rotation and taper of the blades.
VI. Designing the hub: Create a hub design that connects the blades in the
center of the propeller. The hub must be simplified aerodynamically to
minimize drag and efficiently transmit power to the blades.
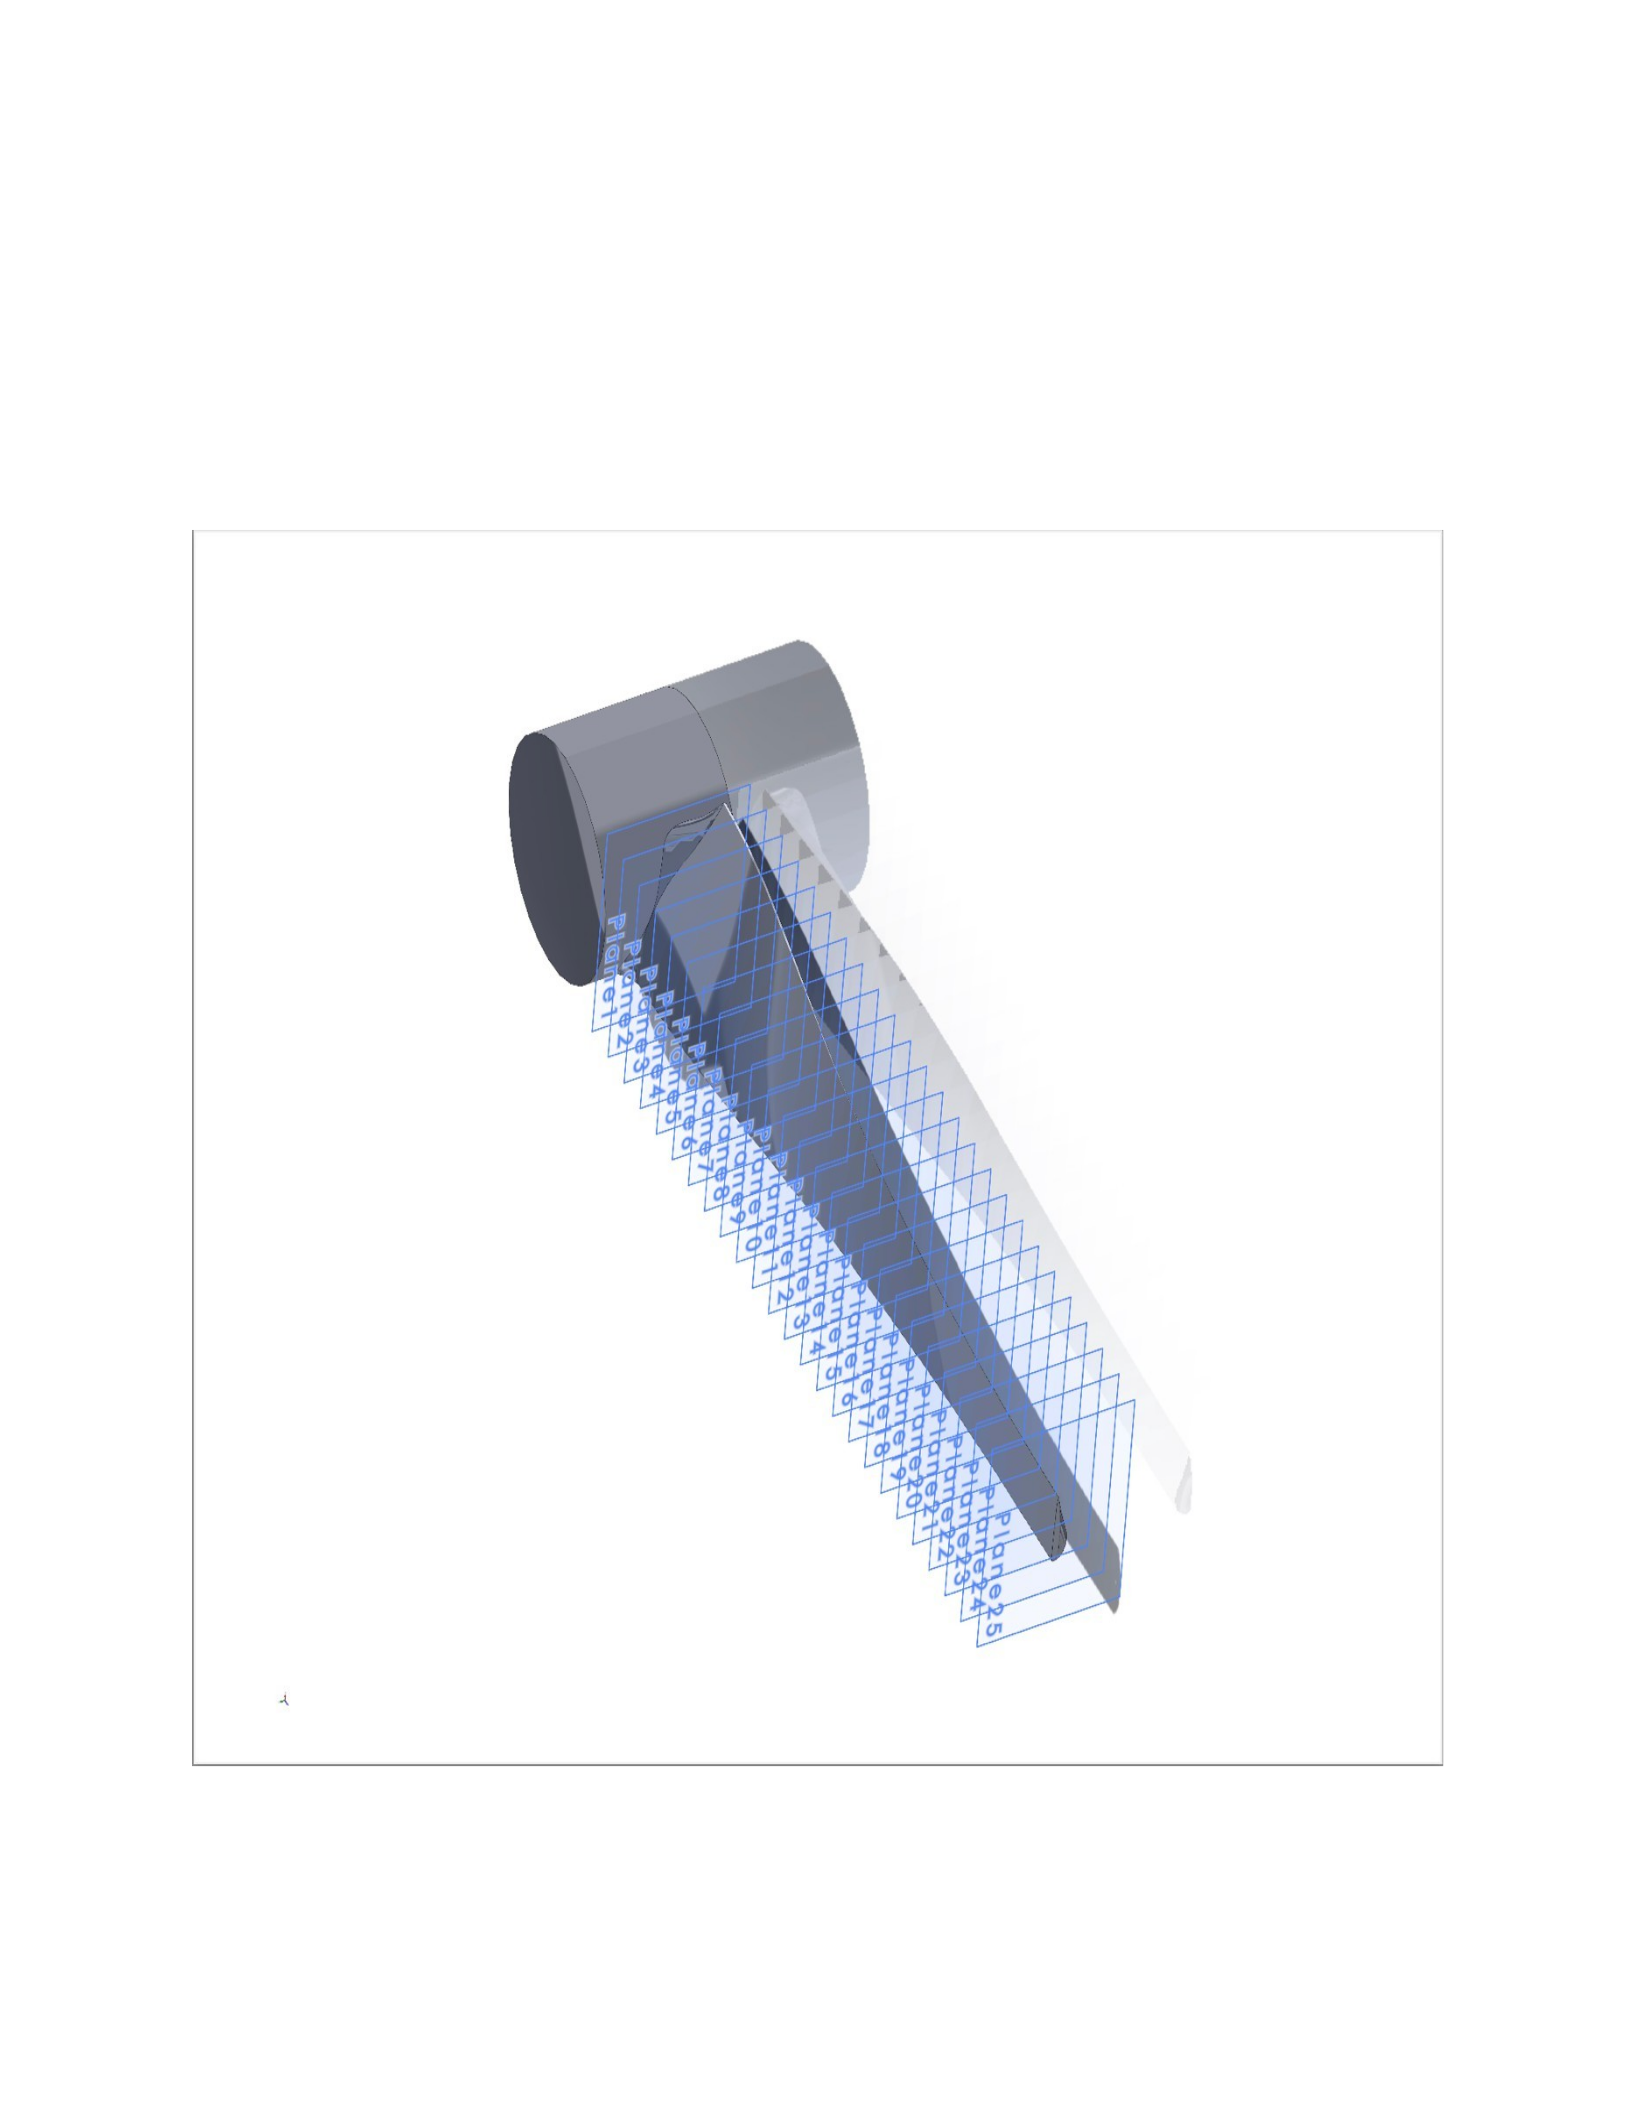
Figure 3.3 SKETCHING THE HYDROFOILS IN THEIR RESPECTIVE FIELDS USING
SOLIDWORKS.
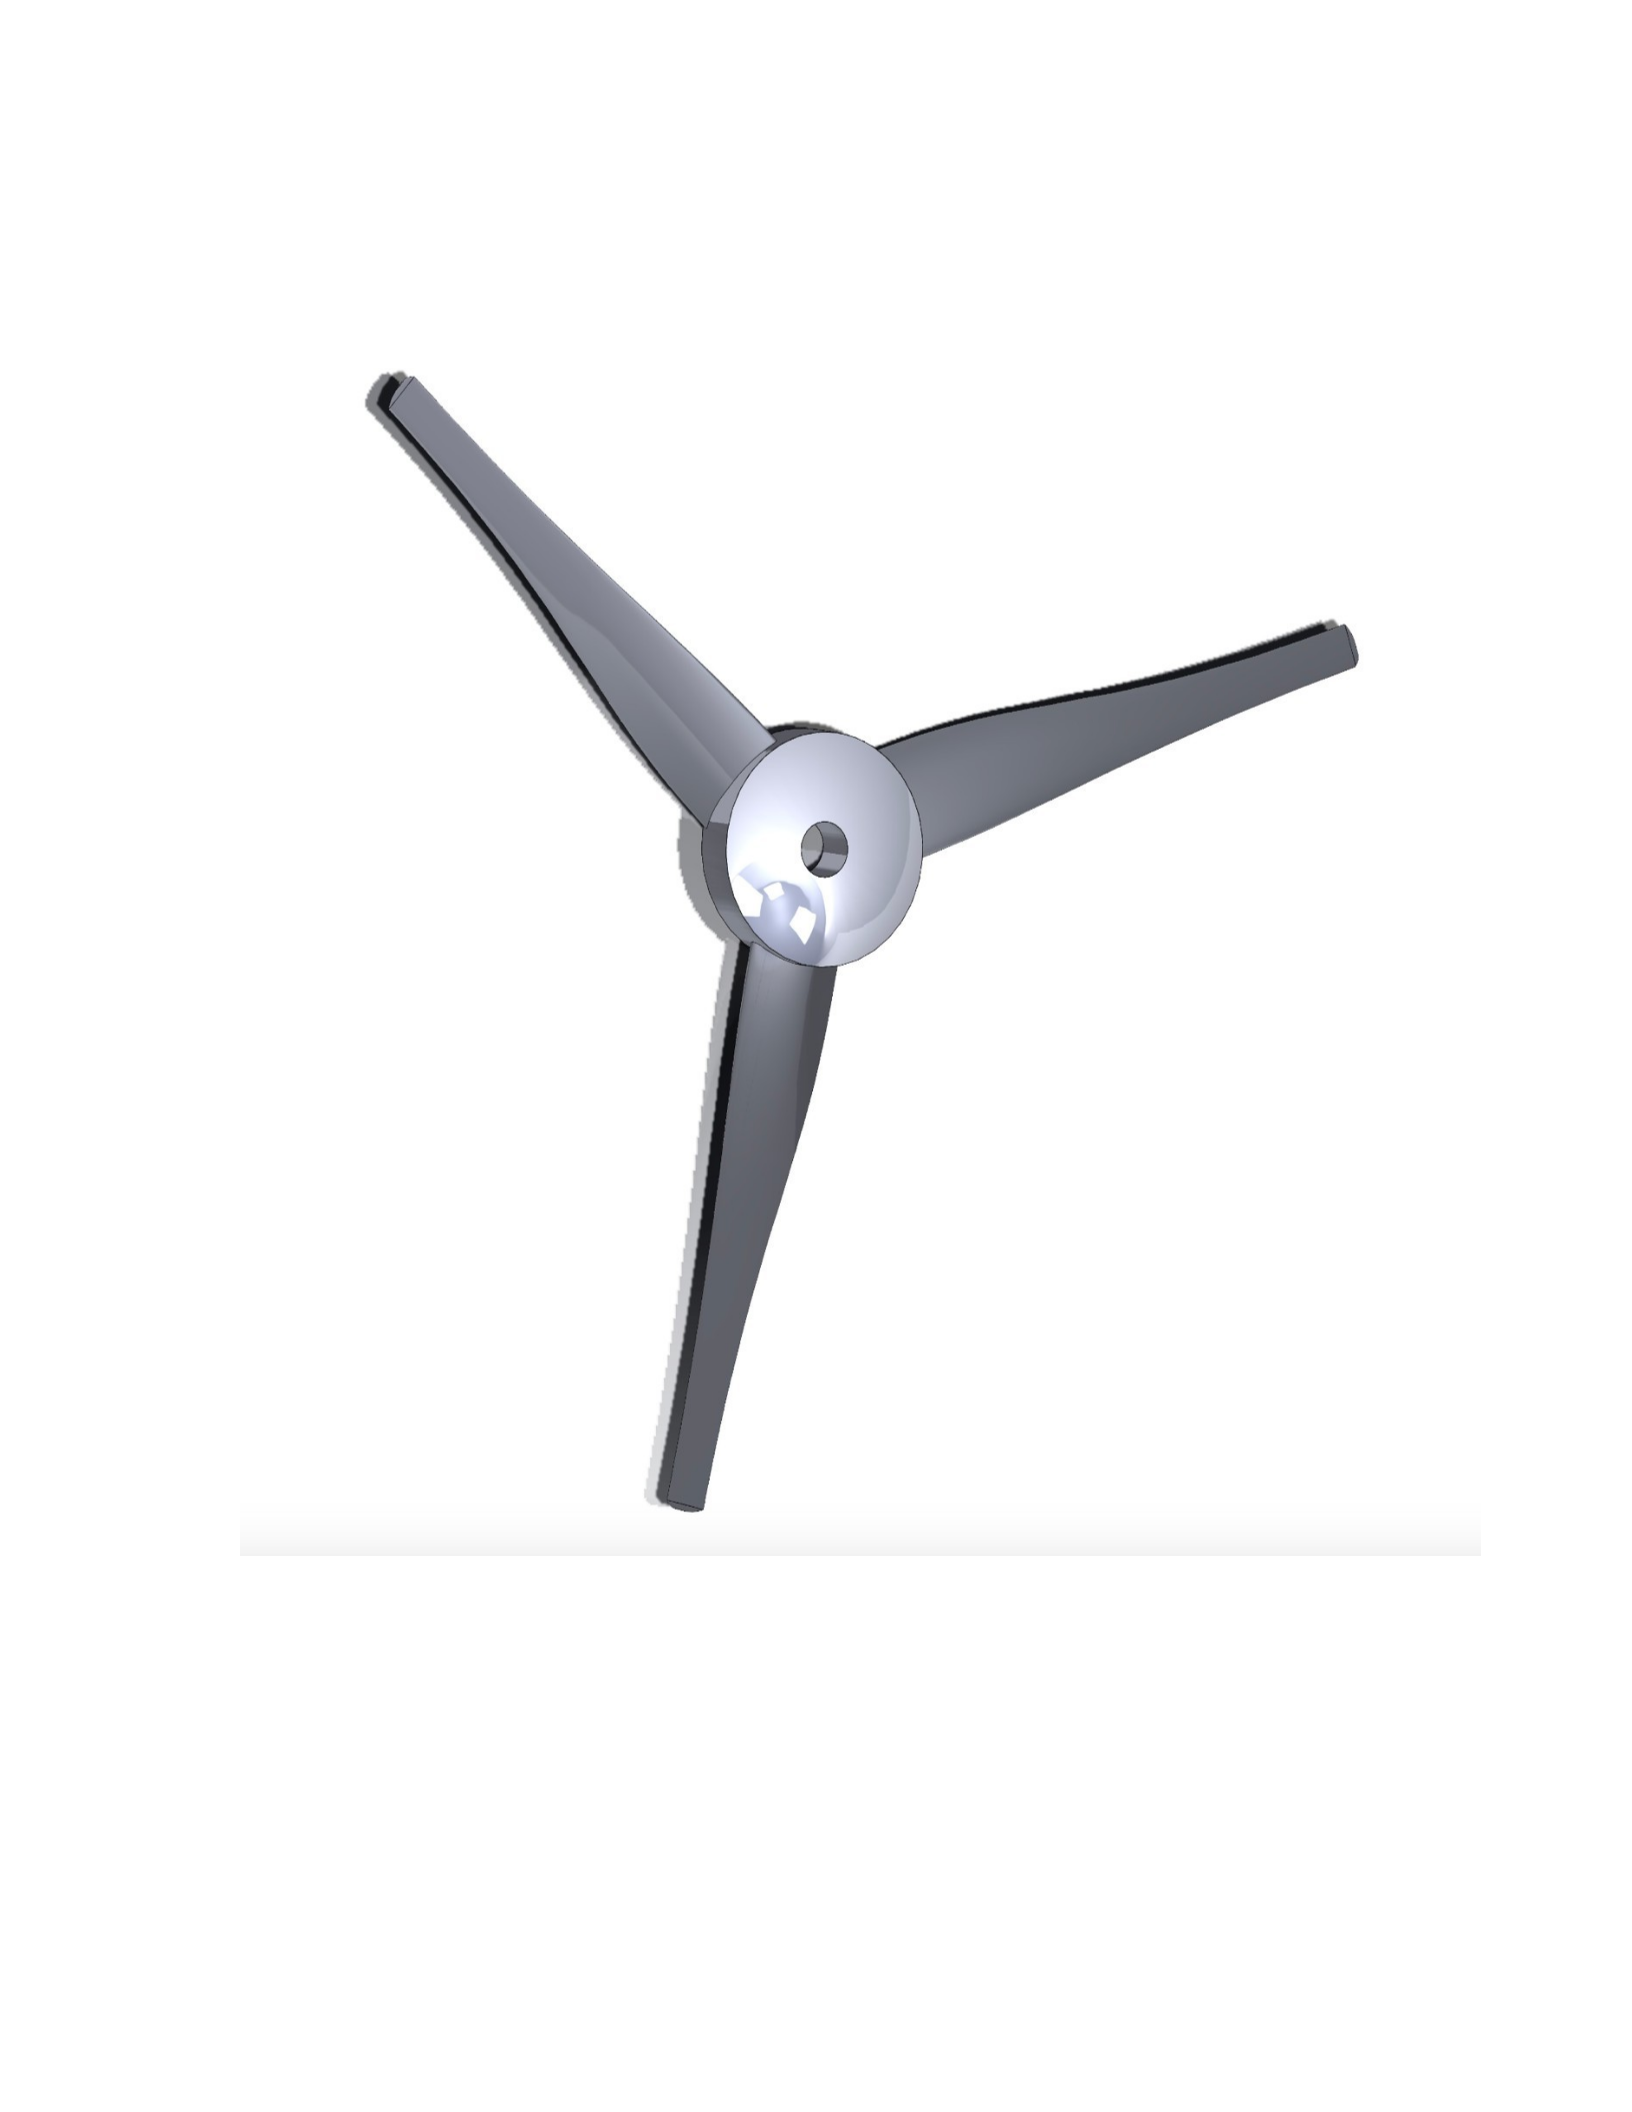
43
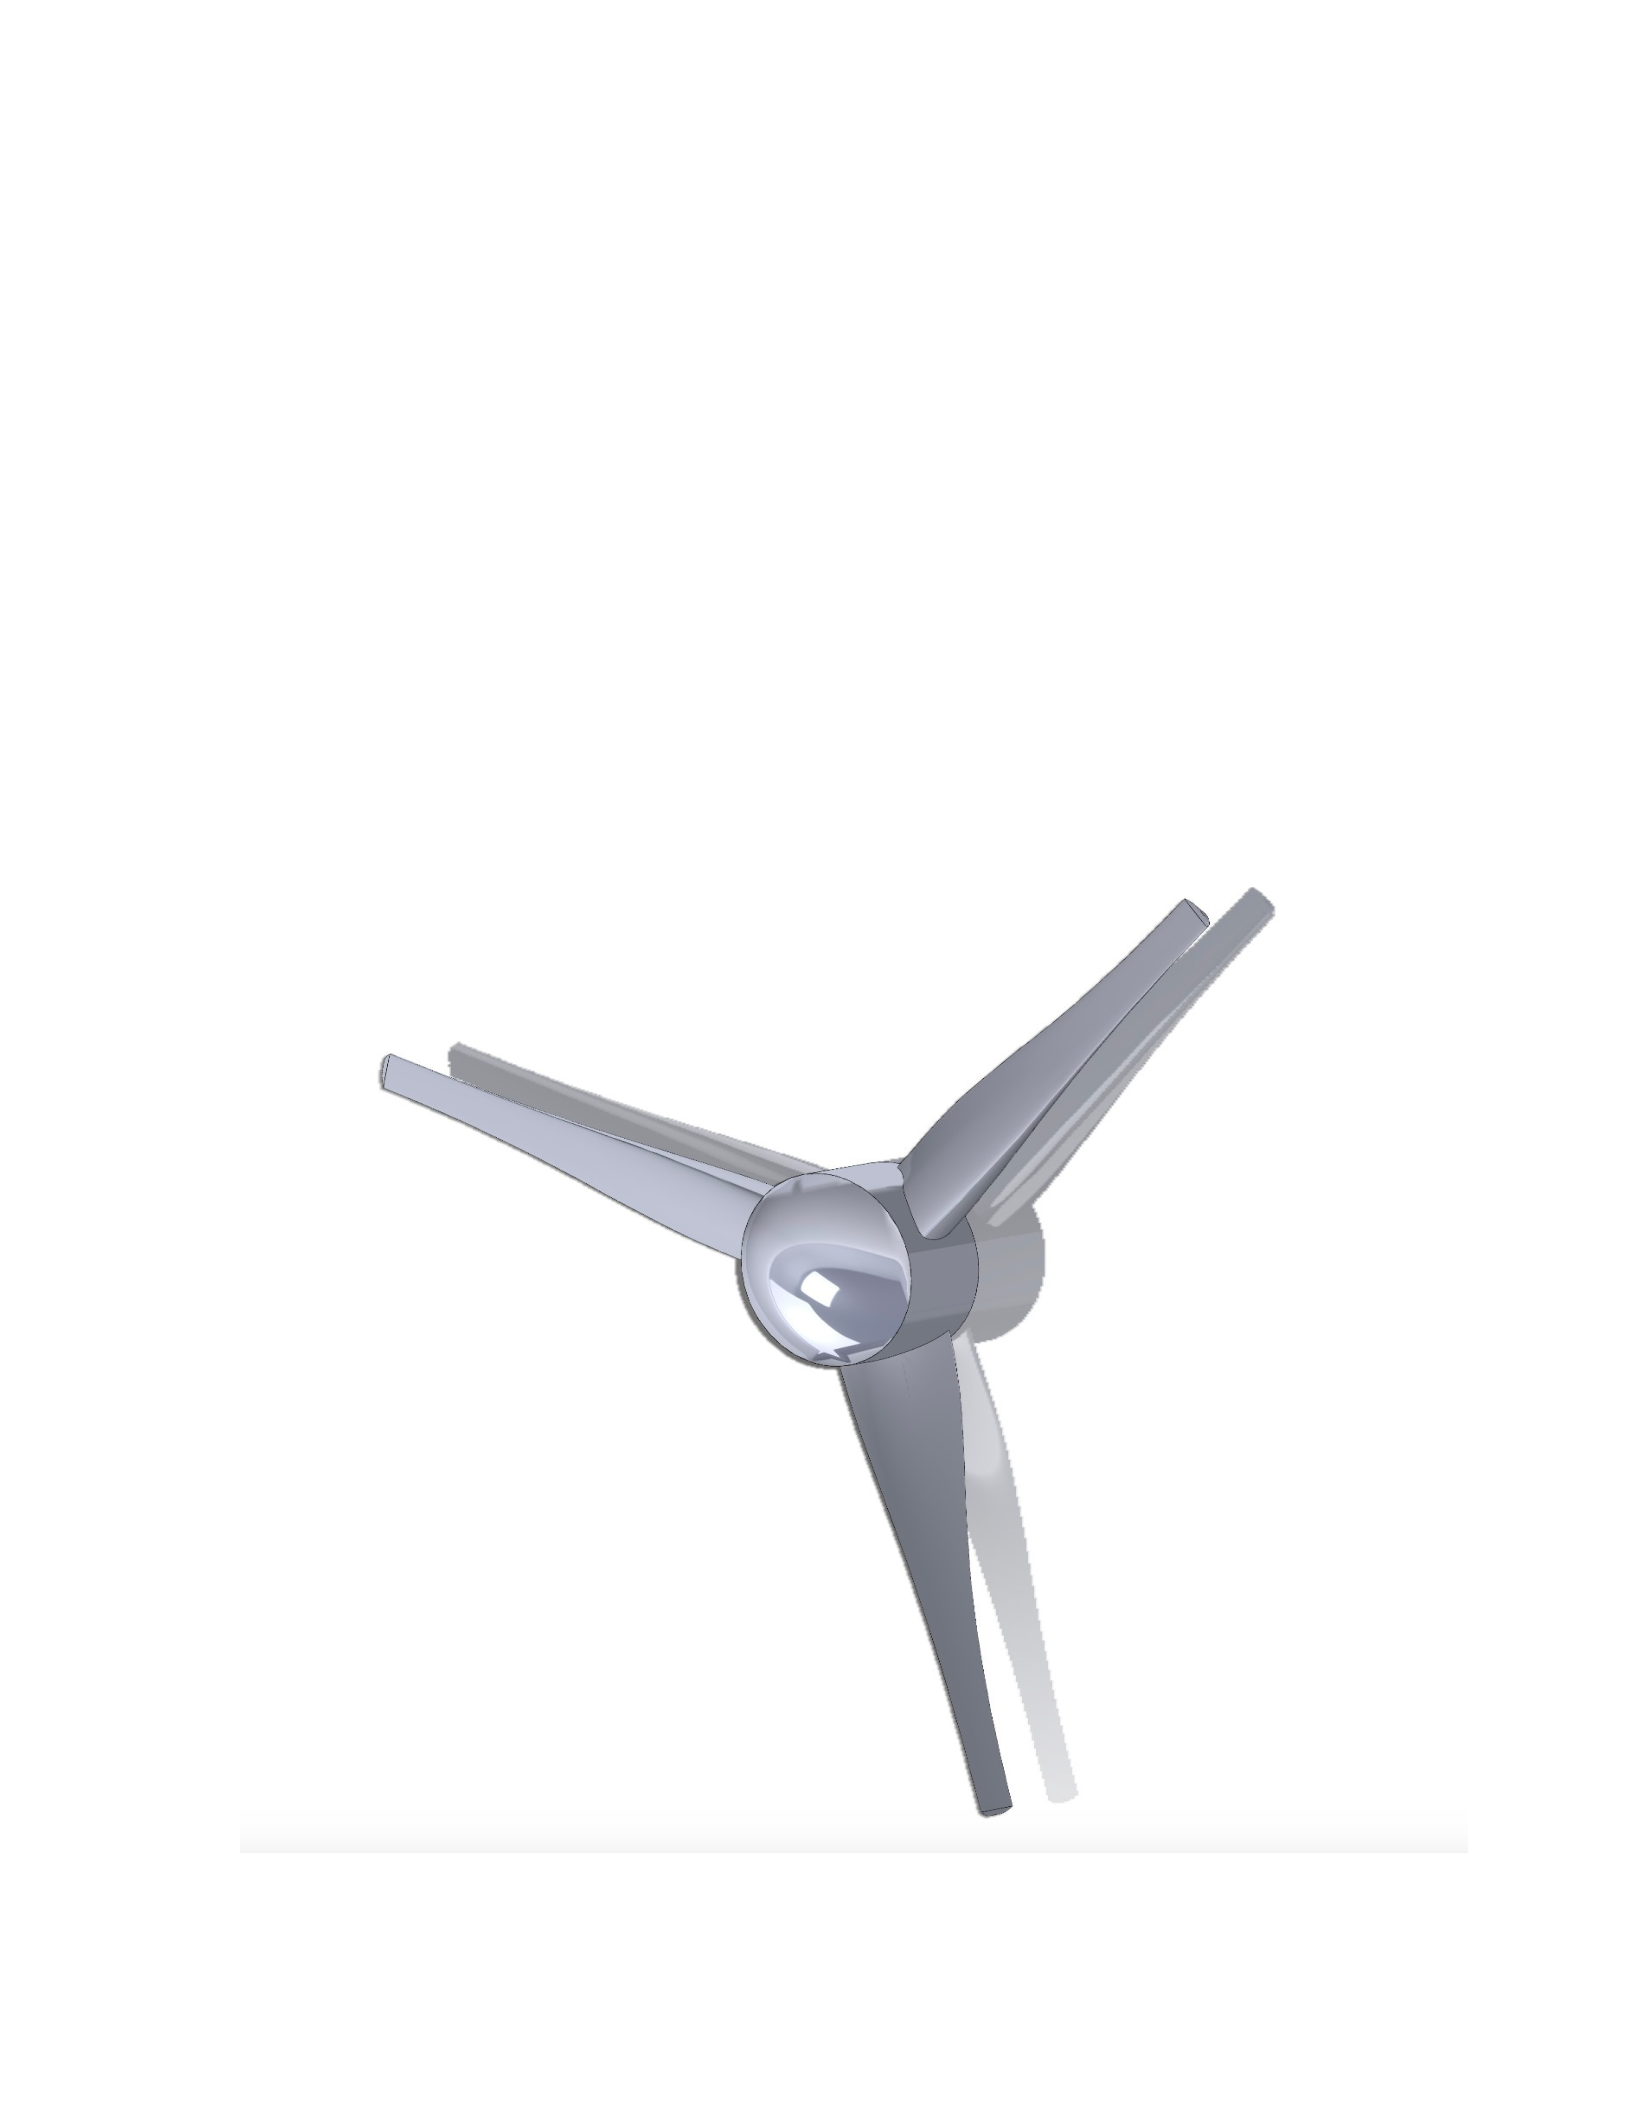
VII. Assembling the Blades and Hubs: In this step, we assemble the blades
and hubs in SolidWorks to create a complete propeller assembly. Make
sure the bars are evenly placed around the hub and are properly oriented.
Figure 3.4 COMPLETE 3-BLADE ROTOR WITHOUT NOSE.
44
VIII. Applying the Fillet: In this step, we need to add the fillet, root and end
fairing, and other necessary features to the propeller blades and hub to
ensure smooth airflow and structural integrity.
IX. Perform a Structural Analysis: Perform a structural analysis of the blade
to evaluate its ability to withstand the load and pressure it will face
during operation. SolidWorks' finite element analysis (FEA)
capabilities can be used for this purpose.
X. Aerodynamic Characterization Evaluation: Use computational fluid
dynamics (CFD) software (we used Javafoil and Ansys (Fluent)), to
simulate the aerodynamic performance of variable geometry blades.
Analyze lift, resistance and other flow characteristics along the blade
span.
Figure 3.5 3-BLADE ROTOR COMPLETE WITH NOSE.

45
XI. Optimization: use optimization tools in SolidWorks or external
optimization software to fine-tune the profile and geometry of the
airfoil blade to achieve optimal performance. The goal is to balance
the trade-off between lifting, barriers, and structural integrity.
XII. Design Validation: Create and test a prototype of a variable geometry
bar under controlled conditions using a 3D printer to validate its
performance. Collect data on lift, drag, efficiency, torque, and power.
XIII. Iteration and Refinement: Based on the results of the prototype testing,
we need to make the necessary adjustments to the SolidWorks model
and repeat the validation process as needed. Iteration is often required to
achieve the desired performance.
XIV. Documentation: Document our designs thoroughly, including
drawings, specifications, airfoil data, and analysis results. This
documentation is essential for future manufacturing and reference.
46
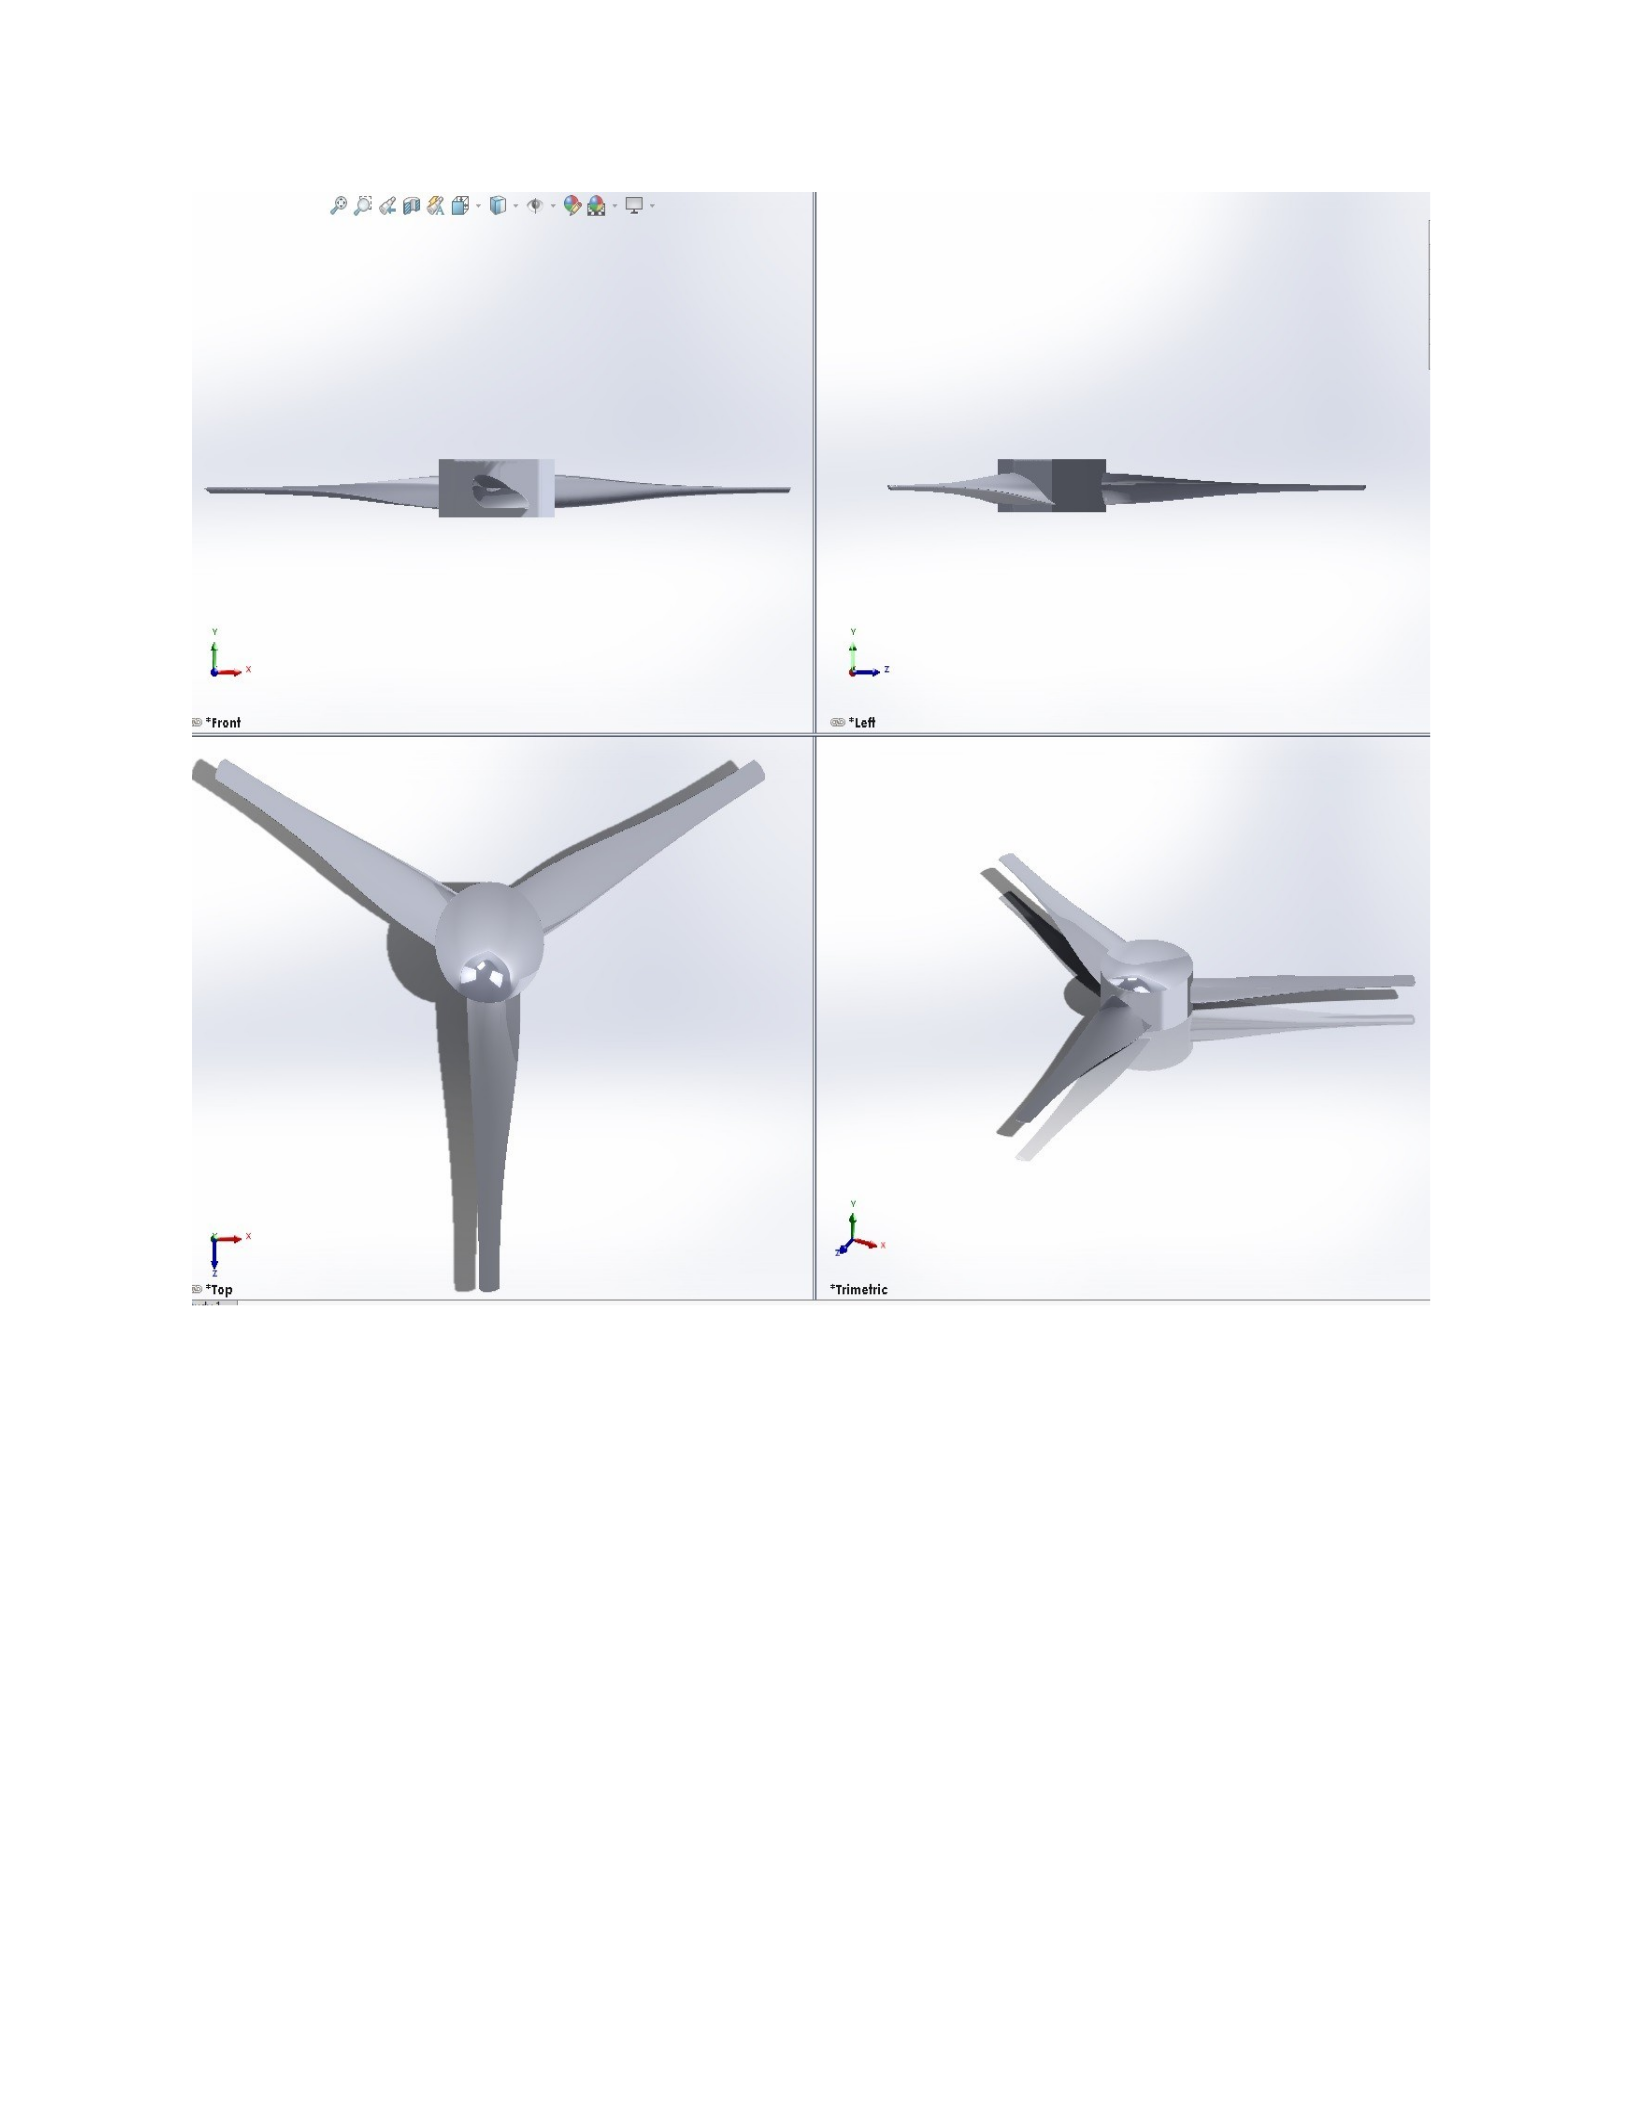
IMAGE 3.6 FINISHED 3D BLADE OF VARIOUS VIEWS.
47
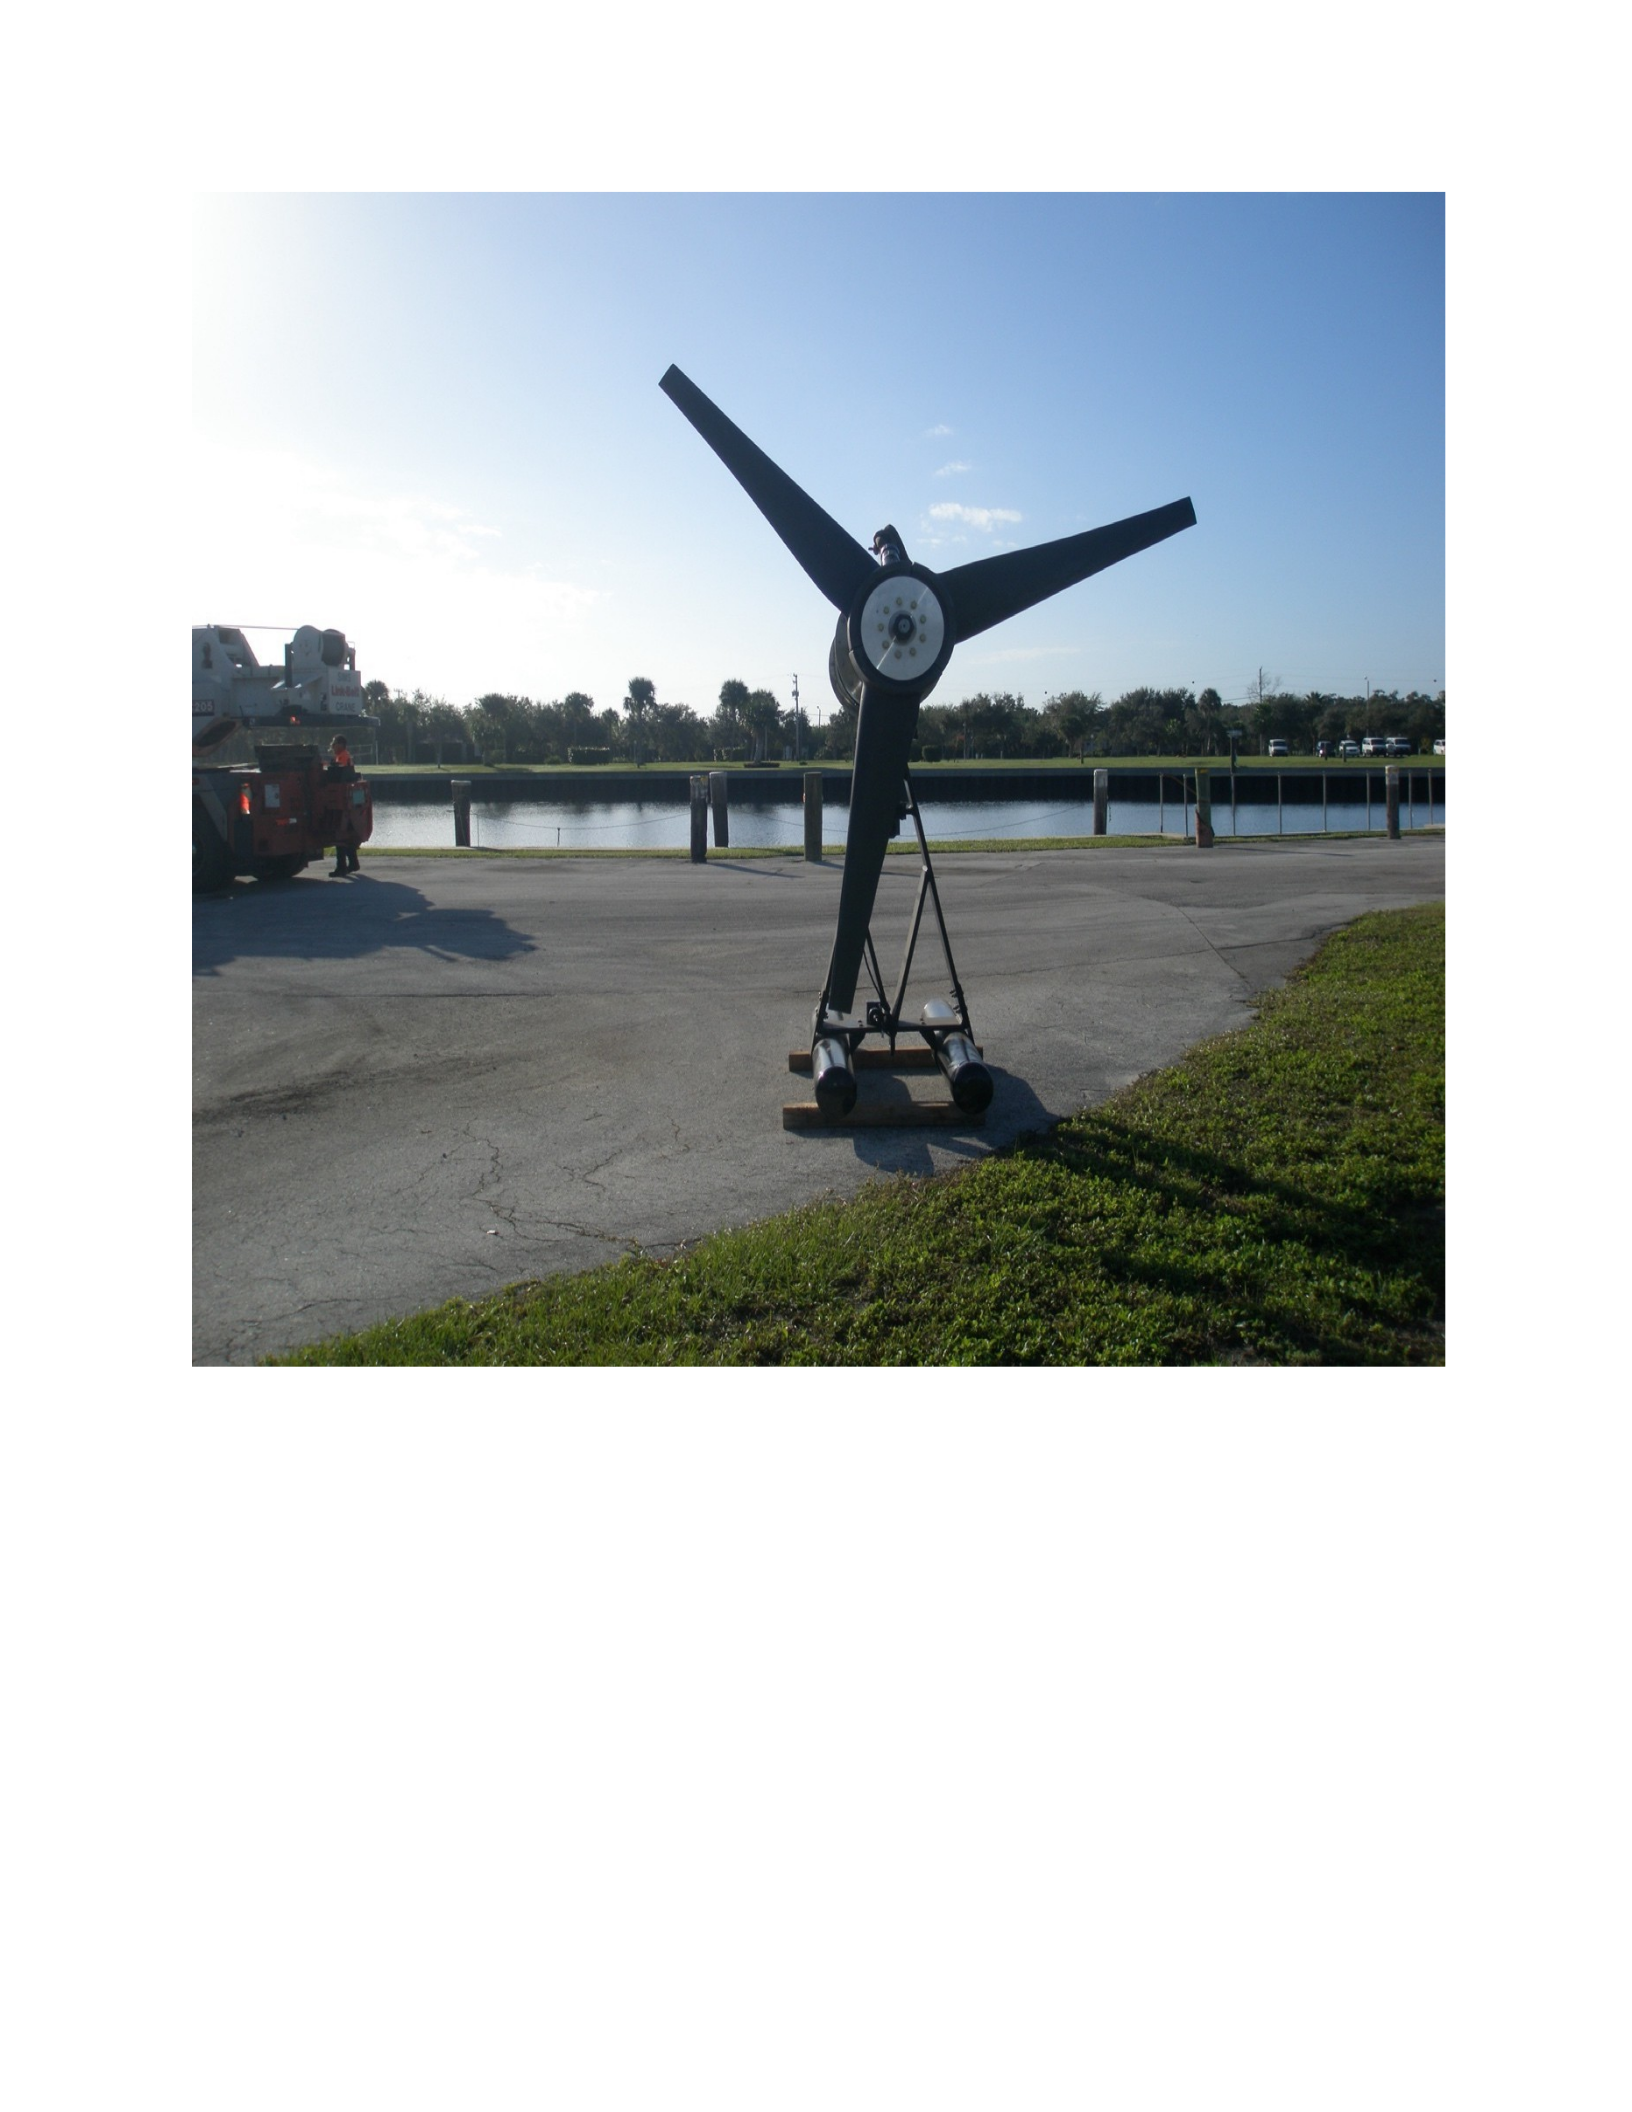
Figure 3.7 (Photo taken by Dr. VanZweieten)
Figure 3.6 shows a life-size underwater current turbine run by Florida Atlantic University. The
rotor is attached to the downstream side of the turbine which means it is at the rear of the
turbine during operation.
3.2 Choosing Materials

48
3D printers use a variety of materials with their unique properties and characteristics. These
materials exhibit a wide range of mechanical, thermal, and chemical properties, making them
suitable for a wide range of 3D printing applications in a variety of industries. The selection of a
particular material depends on the desired characteristics of the final product and the 3D printing
technology used. The materials mentioned below are some of the common materials used in 3D
printing at the University of New Orleans that we consider making propellers:
I. PLA (Polylactic Acid): PLA is a bioactive thermoplastic made from renewable resources
such as cornstarch or sugarcane. It is known for its ease of printing, relatively low melting
temperature (around 180-220°C), and good dimensional stability. PLA is commonly used for
prototypes, consumer goods, and educational purposes.
II. ABS (Acrylonitrile Butadiene Styrene): ABS is a tough, impact-resistant thermoplastic
with a higher melting point than PLA (around 220-250°C). It is widely used in industrial
applications, automotive parts, and consumer products. ABS requires a heated build platform to
prevent warping during printing.
III. PETG (Polyethylene Terephthalate Glycol-Modified): PETG material combines the
strength of ABS with the ease of PLA printing. It is a better choice for us to make a
propeller, because, it has better chemical resistance and durability compared to the two
options mentioned earlier, making it suitable for functional parts, mechanical components,
and food-safe containers.
IV. Resin: Resin-based 3D printing, such as stereolithography (SLA) uses a photopolymer
resin that hardens when exposed to ultraviolet (UV) light. These materials offer high resolution
and are used in applications such as dental models, jewelry, and detailed prototypes.
V. Carbon Fiber Reinforced Polymers: Carbon Fiber Reinforced Polymers (CFRP) are
composite materials composed of carbon fibers embedded in a polymer matrix. Its outstanding
Strength-to-weight ratio, stiffness, low density, corrosion resistance, and fatigue resistance make
it an excellent choice for applications in the aerospace, automotive, marine industries. Its
properties can be adjusted by adjusting the fiber orientation, density, and type of polymer matrix
used. The main reinforcing element in CFRP is carbon fiber. These fibers are made of carbon
atoms arranged in a crystalline structure. They are very strong, with a higher tensile strength
than steel, yet much lighter. Carbon fiber is produced through processes such as oxidation of
precursor materials or pyrolysis of natural fibers. The choice of precursors and manufacturing
processes affect the properties of carbon fiber. Common polymer matrices used in CFRP
include epoxy, polyester, vinyl ester, and more. Epoxy resins are widely chosen for their
excellent adhesion to carbon fibers, low shrinkage, and high temperature resistance.
Mechanical properties of carbon fiber reinforced polymers:
Carbon Fiber Reinforced Polymers (CFRP) consist of carbon fibers, bonded with resins, to create
innovative materials that have been proven to have endless application possibilities in a variety
of composite cutting industries. Due to its attractive properties of strength, durability,
49
corrosion resistance, and its mild nature, there has been an increase in the use of carbon fiber in
the aerospace and automotive industries. However, it does not come without its own set of
challenges compared to metal machining in general. [5] Carbon fiber has high strength (3–7
GPa), high modulus (200–500 GPa), compressive strength (1–3 GPa), shear modulus (10–15
GPa), and low density (1.75–2.00 g/cm3). Carbon fiber made of pitch can have modulus,
thermal, and electrical conductivity as high as 900 GPa, 1,000 W/mK, and 106 S/m, respectively.
These fibers have become the dominant material in the aerospace industry and their use in the
automotive and other industries is growing as their costs continue to fall. [6] CFRP is
characterized by its high stiffness, often measured as modulus of elasticity. This property is
especially important for applications that require minimal stiffness and deformation under load.
They are lightweight materials due to their low carbon fiber density and polymer matrix. Its low
mass, coupled with its high strength and rigidity, makes it ideal for applications where weight
reduction is critical, such as the aerospace and automotive industries. CFRP is highly resistant to
corrosion, which is an important advantage compared to materials such as steel and aluminum.
This property makes it suitable for marine and chemical industry applications.
CFRP has good fatigue resistance, meaning it can withstand cyclic loads without experiencing
significant degradation in performance. This characteristic is especially important for
applications that are subjected to repeated stress.
Modulus longitudinal, E, (GPa) 160
Transverse modulus, Ez (GPa) 8.97
Shear modulus in plane, Giz (GPa) 6.21
Rasio Middle Poison 0.28
Longitudinal tensile strength (MPa) 2843
Longitudinal compressive strength
(MPa)
1553
Transverse tensile strength (MPa) 166
Transverse compressive strength
(MPa)
600
Shear strength, S (MPa) 200
Density, (kg/m3) 1530
Maximum degradation, D 0.7
Table 3.1: Mechanical Properties of CFRP
3.3 3D Printing Results
To build the propellers on a small scale, we used different 3D printers at NAME and the
Department of Mechanical Engineering at the University of New Orleans. But the final and best
result is made by the Stratasys F170 printer. We chose carbon fiber as a material because of its
many advantages that align with the specific requirements we were looking to conduct our
experiments on including stiffness, strength, and fatigue resistance. Also, to reduce the overall
weight of the propulsion system resulting in improved performance and efficiency
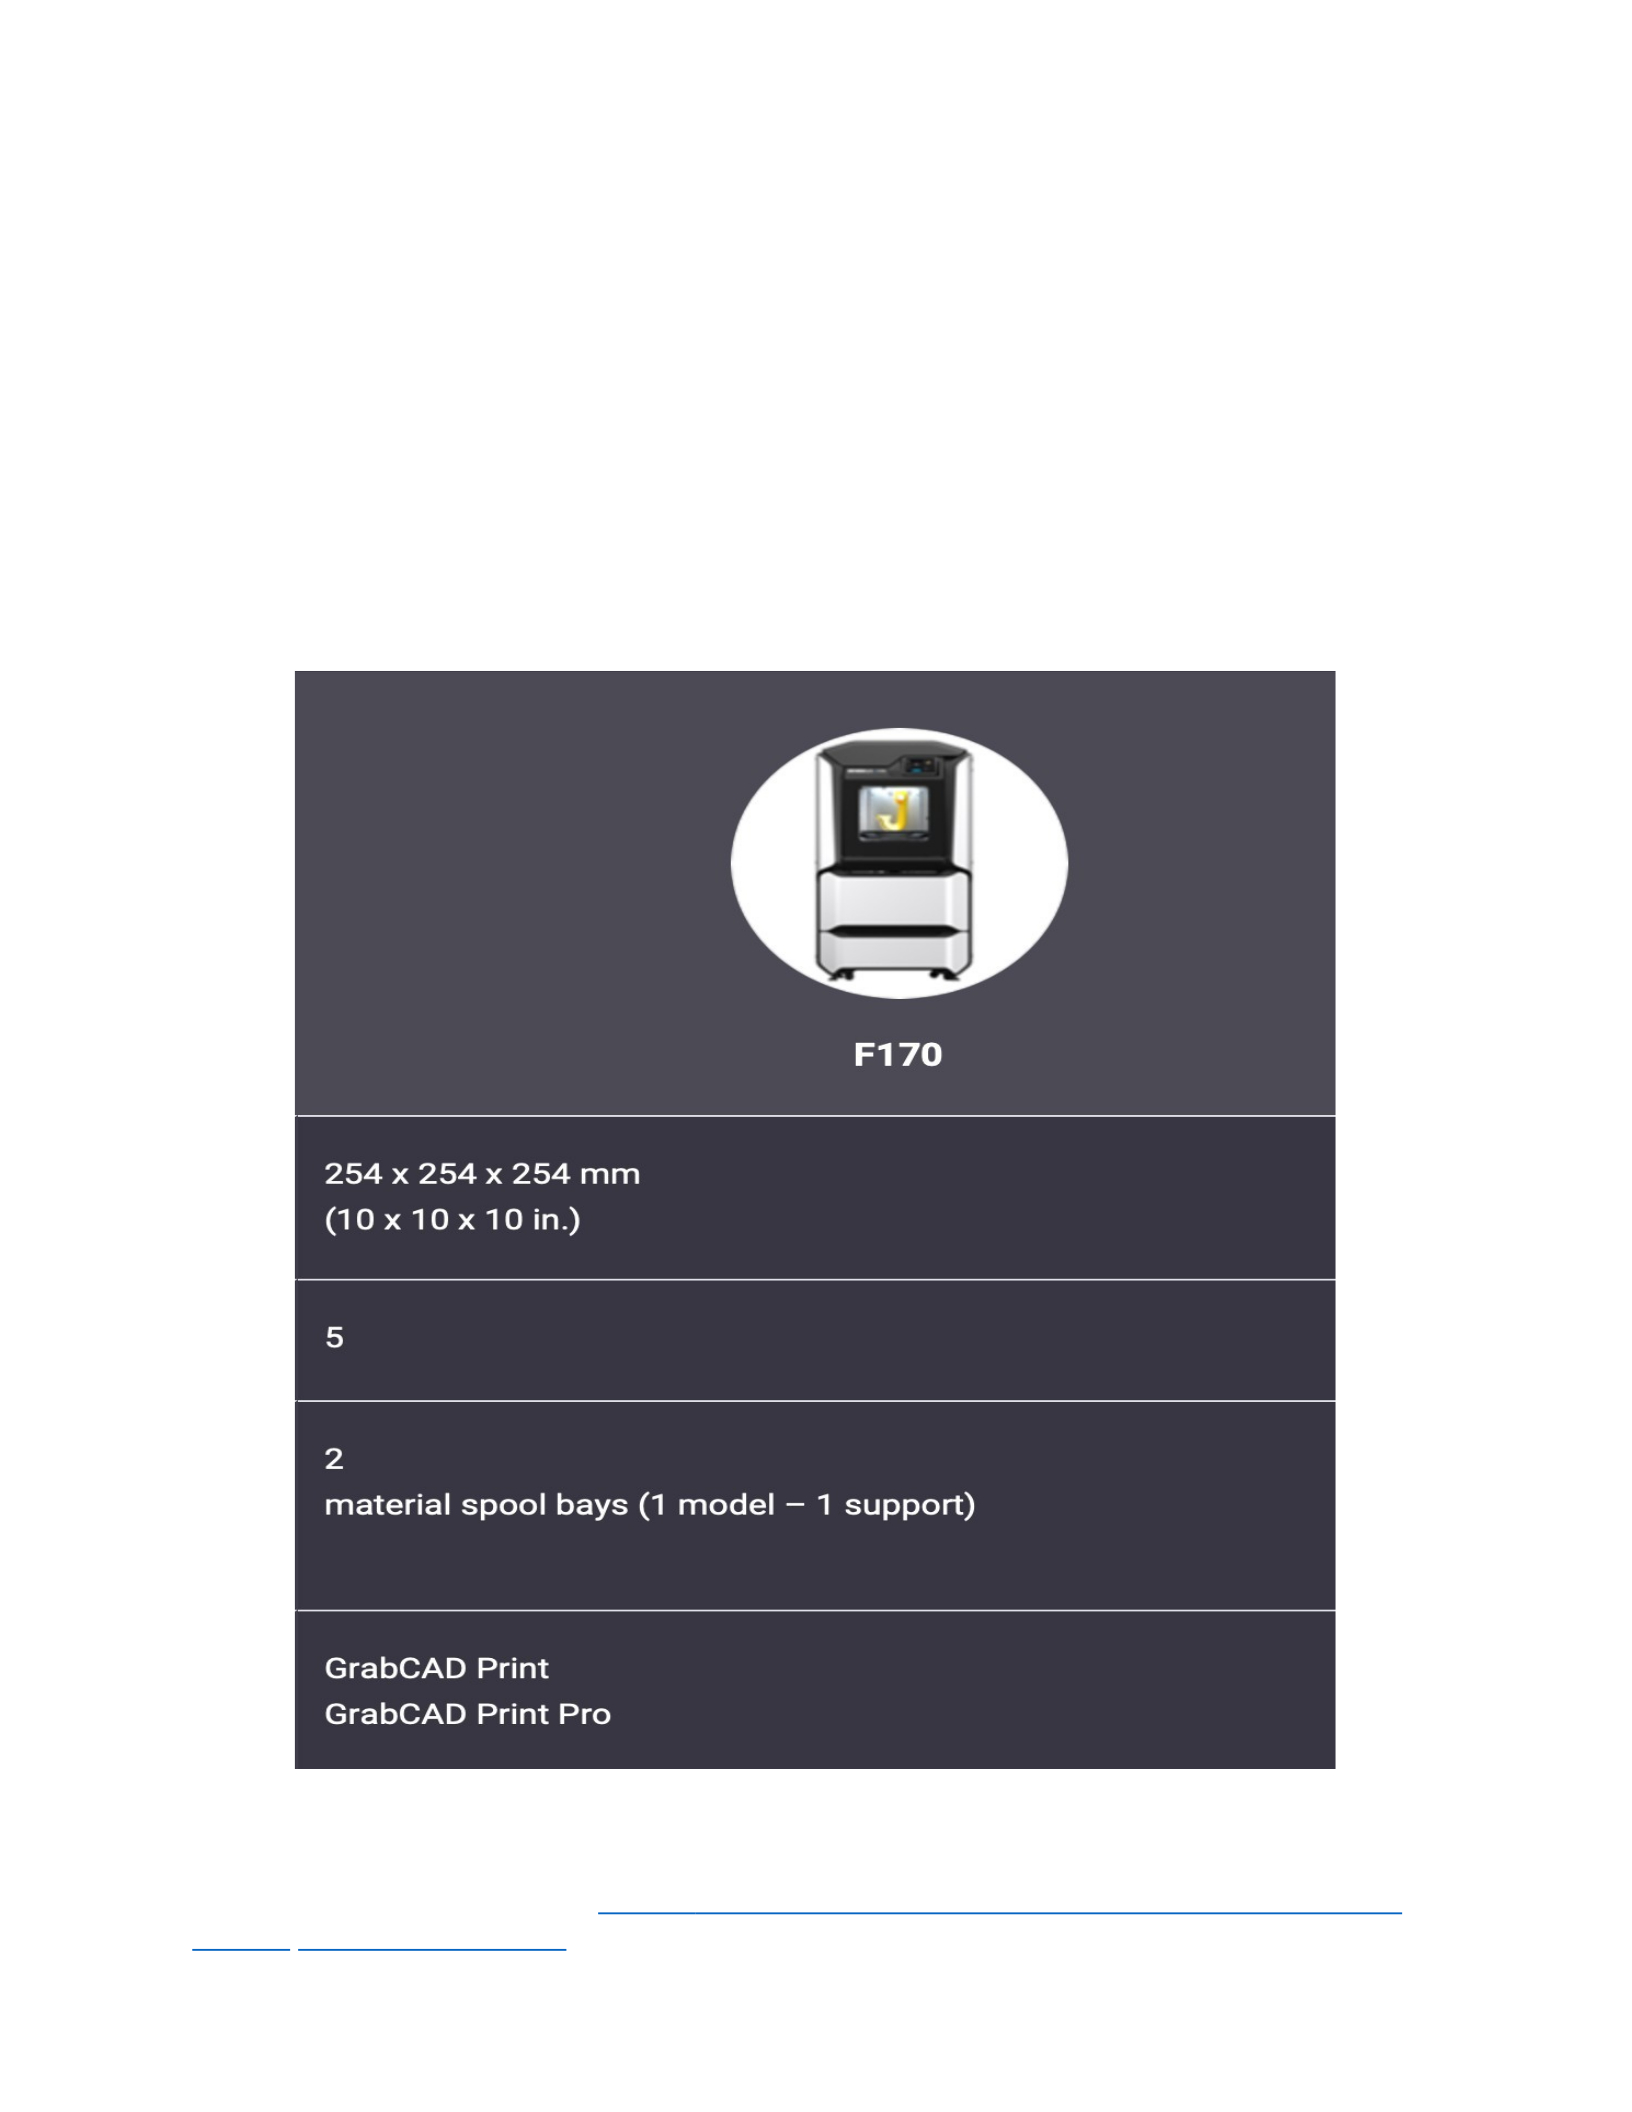
50
Of these systems, carbon fiber is a good candidate because of its exceptional strength-to-weight
ratio. This material is significantly lighter than many traditional materials such as metals while
still retaining impressive structural integrity. The high tensile strength of carbon fiber allows for
the construction of thin and lightweight blades that can withstand the hydrodynamic forces
experienced during experiments. This strength-to-weight advantage contributes to improved
performance and reduced wear on the propeller, resulting in cost savings and increased
reliability.
In addition, the propeller blades are subjected to harsh conditions such as towing tank
environments and dynamic loads during trials, special durability, corrosion resistance, and
superior fatigue resistance of carbon fiber ensure a longer operating life.
Figure 3.8 Stratasys F170 Printer
The Stratasys F170 3D printer (https:// www.stratasys.com/en/3d-printers/printer-catalog/fdm-
printers /f123-series-printers/) is a cutting-edge additive manufacturing device included in the

51
FDM (Fused Deposition Modeling) family of 3D printing technologies. Manufactured by
Stratasys, a leading provider of 3D printing solutions, the F170 is renowned for its reliability,
ease of use, and versatility, making it a valuable asset for professionals in a variety of industries.
One of the key mechanical properties that sets the Stratasys F170 apart is its powerful build
volume. With a maximum build size of 254 x 254 x 254 mm (10 x 10 x 10 inches), this 3D
printer offers substantial workspace, allowing users to create larger prototypes or multiple
smaller parts simultaneously. This spacious assembly envelope increases the flexibility of the
printer, making it suitable for a wide range of applications, from rapid prototyping to producing
functional end-use parts.
The F170 uses coating resolutions ranging from 0.127 mm (0.005 inches) to 0.33 mm (0.013
inches), giving users the ability to select the level of detail and surface finish based on their
specific needs. The resolution of these fine layers contributes to the production of highly
intricate and precise 3D printed models. Whether users are prototyping with intricate geometries
or functional components with demanding specifications, the F170's customizable layer
resolution accommodates a spectrum of design needs.
Another standout mechanical property of Stratasys F170 is the use of industrial-grade
thermoplastics. The printer supports a wide range of materials, including ABS (Acrylonitrile
Butadiene Styrene) and ASA (Acrylonitrile Styrene Acrylate), which are known for their
durability, thermal resistance, and suitability for functional prototypes. This high-performance
material makes F170 particularly suitable for applications in engineering, product development
and manufacturing, where the mechanical properties of the molded part are critical.
In terms of mechanical precision, the F170 has a precision linear guide system and a ball screw
Z stage for accurate layer-by-layer deposition. This robust mechanical system ensures
consistent print quality and dimensional accuracy across manufacturing volumes. The printer's
ability to maintain tight tolerances is critical for applications where precise geometry and part-
to-part consistency are paramount.
The F170 is equipped with a soluble backing material option, allowing for easy removal of the
support structure from intricate and complex geometries. This feature simplifies post-
processing, reducing the time and effort required to clean and finish 3D printed parts. Soluble
supporting materials are very beneficial for producing parts with internal channels, overhangs,
and complex structures.
User-friendly features further enhance the mechanical prowess of the Stratasys F170. These
printers incorporate a touchscreen interface that streamlines the printing process, making them
accessible to users of different skill levels. The intuitive interface provides a convenient platform
for job setup, material selection, and monitoring printing progress. This user-centric design
improves efficiency in 3D printing workflows and ensures that operators can harness the full
potential of the F170 without a steep learning curve.
In conclusion, the Stratasys F170 3D printer distinguishes itself by its impressive mechanical
properties, contributing to its reputation as a reliable and versatile additive manufacturing
solution. Powerful build volume, adjustable layer resolution, support for industrial grade
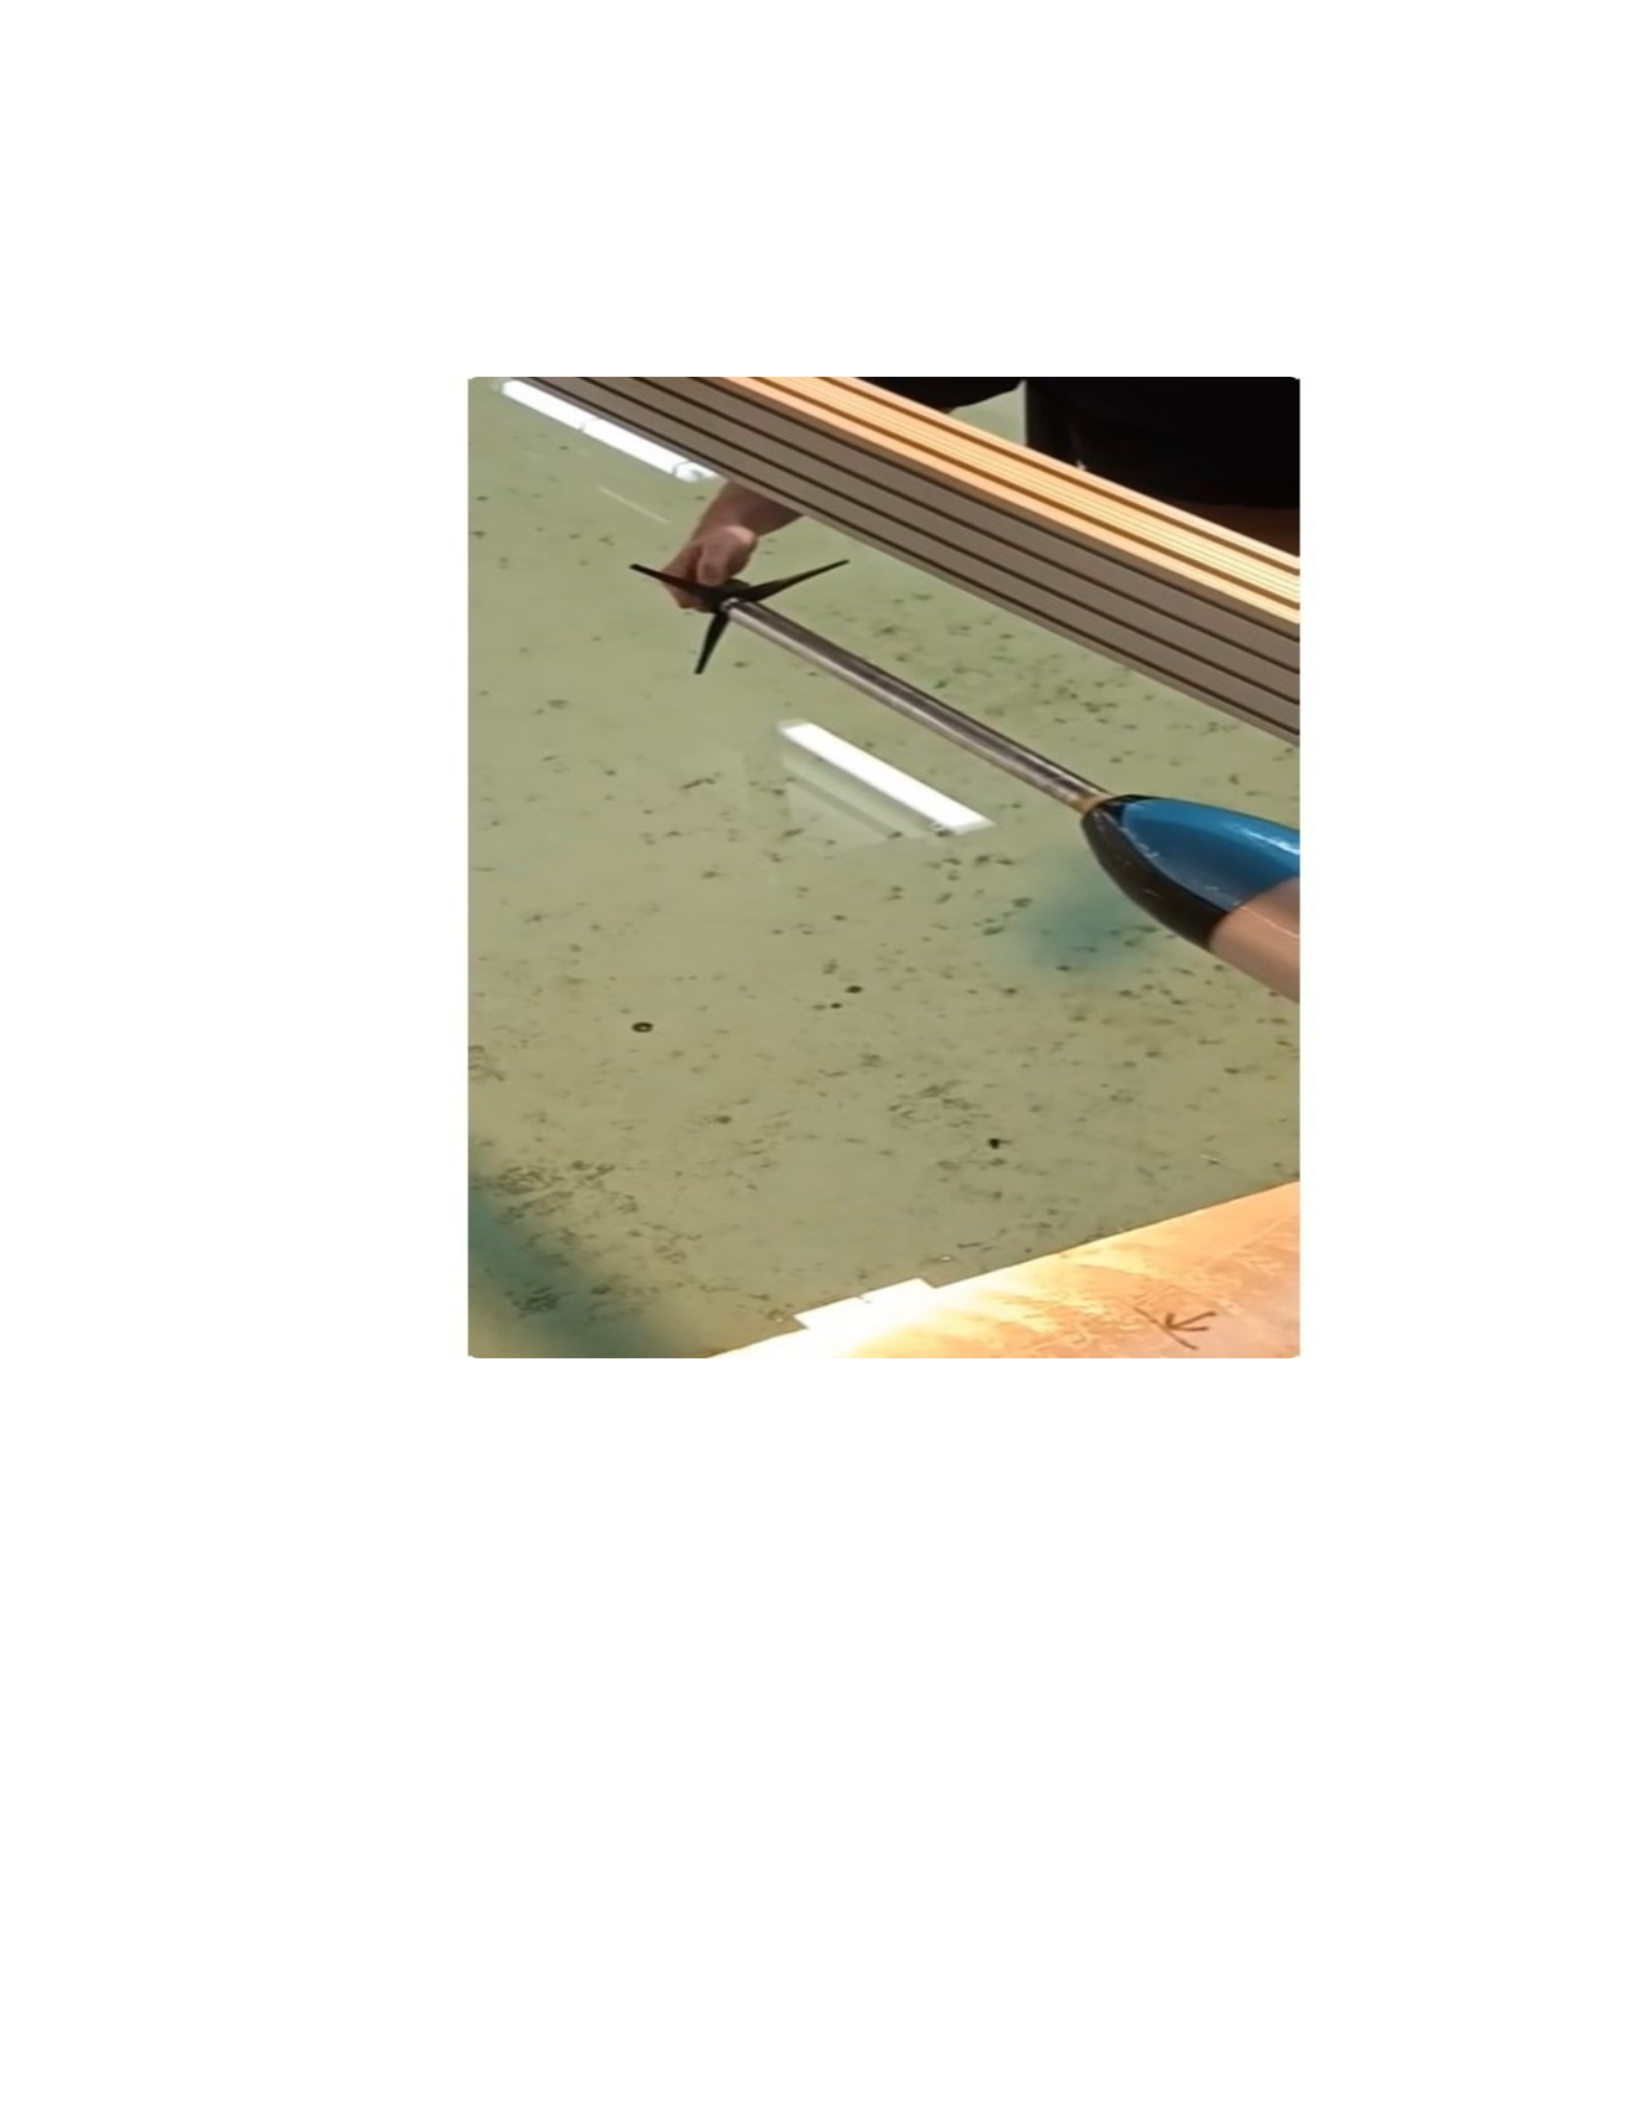
52
thermoplastics, precision linear guidance systems, and user-friendly interfaces collectively make
the F170 well-suited for a wide range of applications in prototyping, product development, and
manufacturing. As technology advances, the Stratasys F170 remains at the forefront,
empowering users to bring their designs to life with precision and efficiency.
Figure 3.9 Attaching the 3D Printing Propeller to the Shaft
Figure 3.9 shows how a 3D printed propeller is mounted on a shaft connected to the turbine
nacelle.
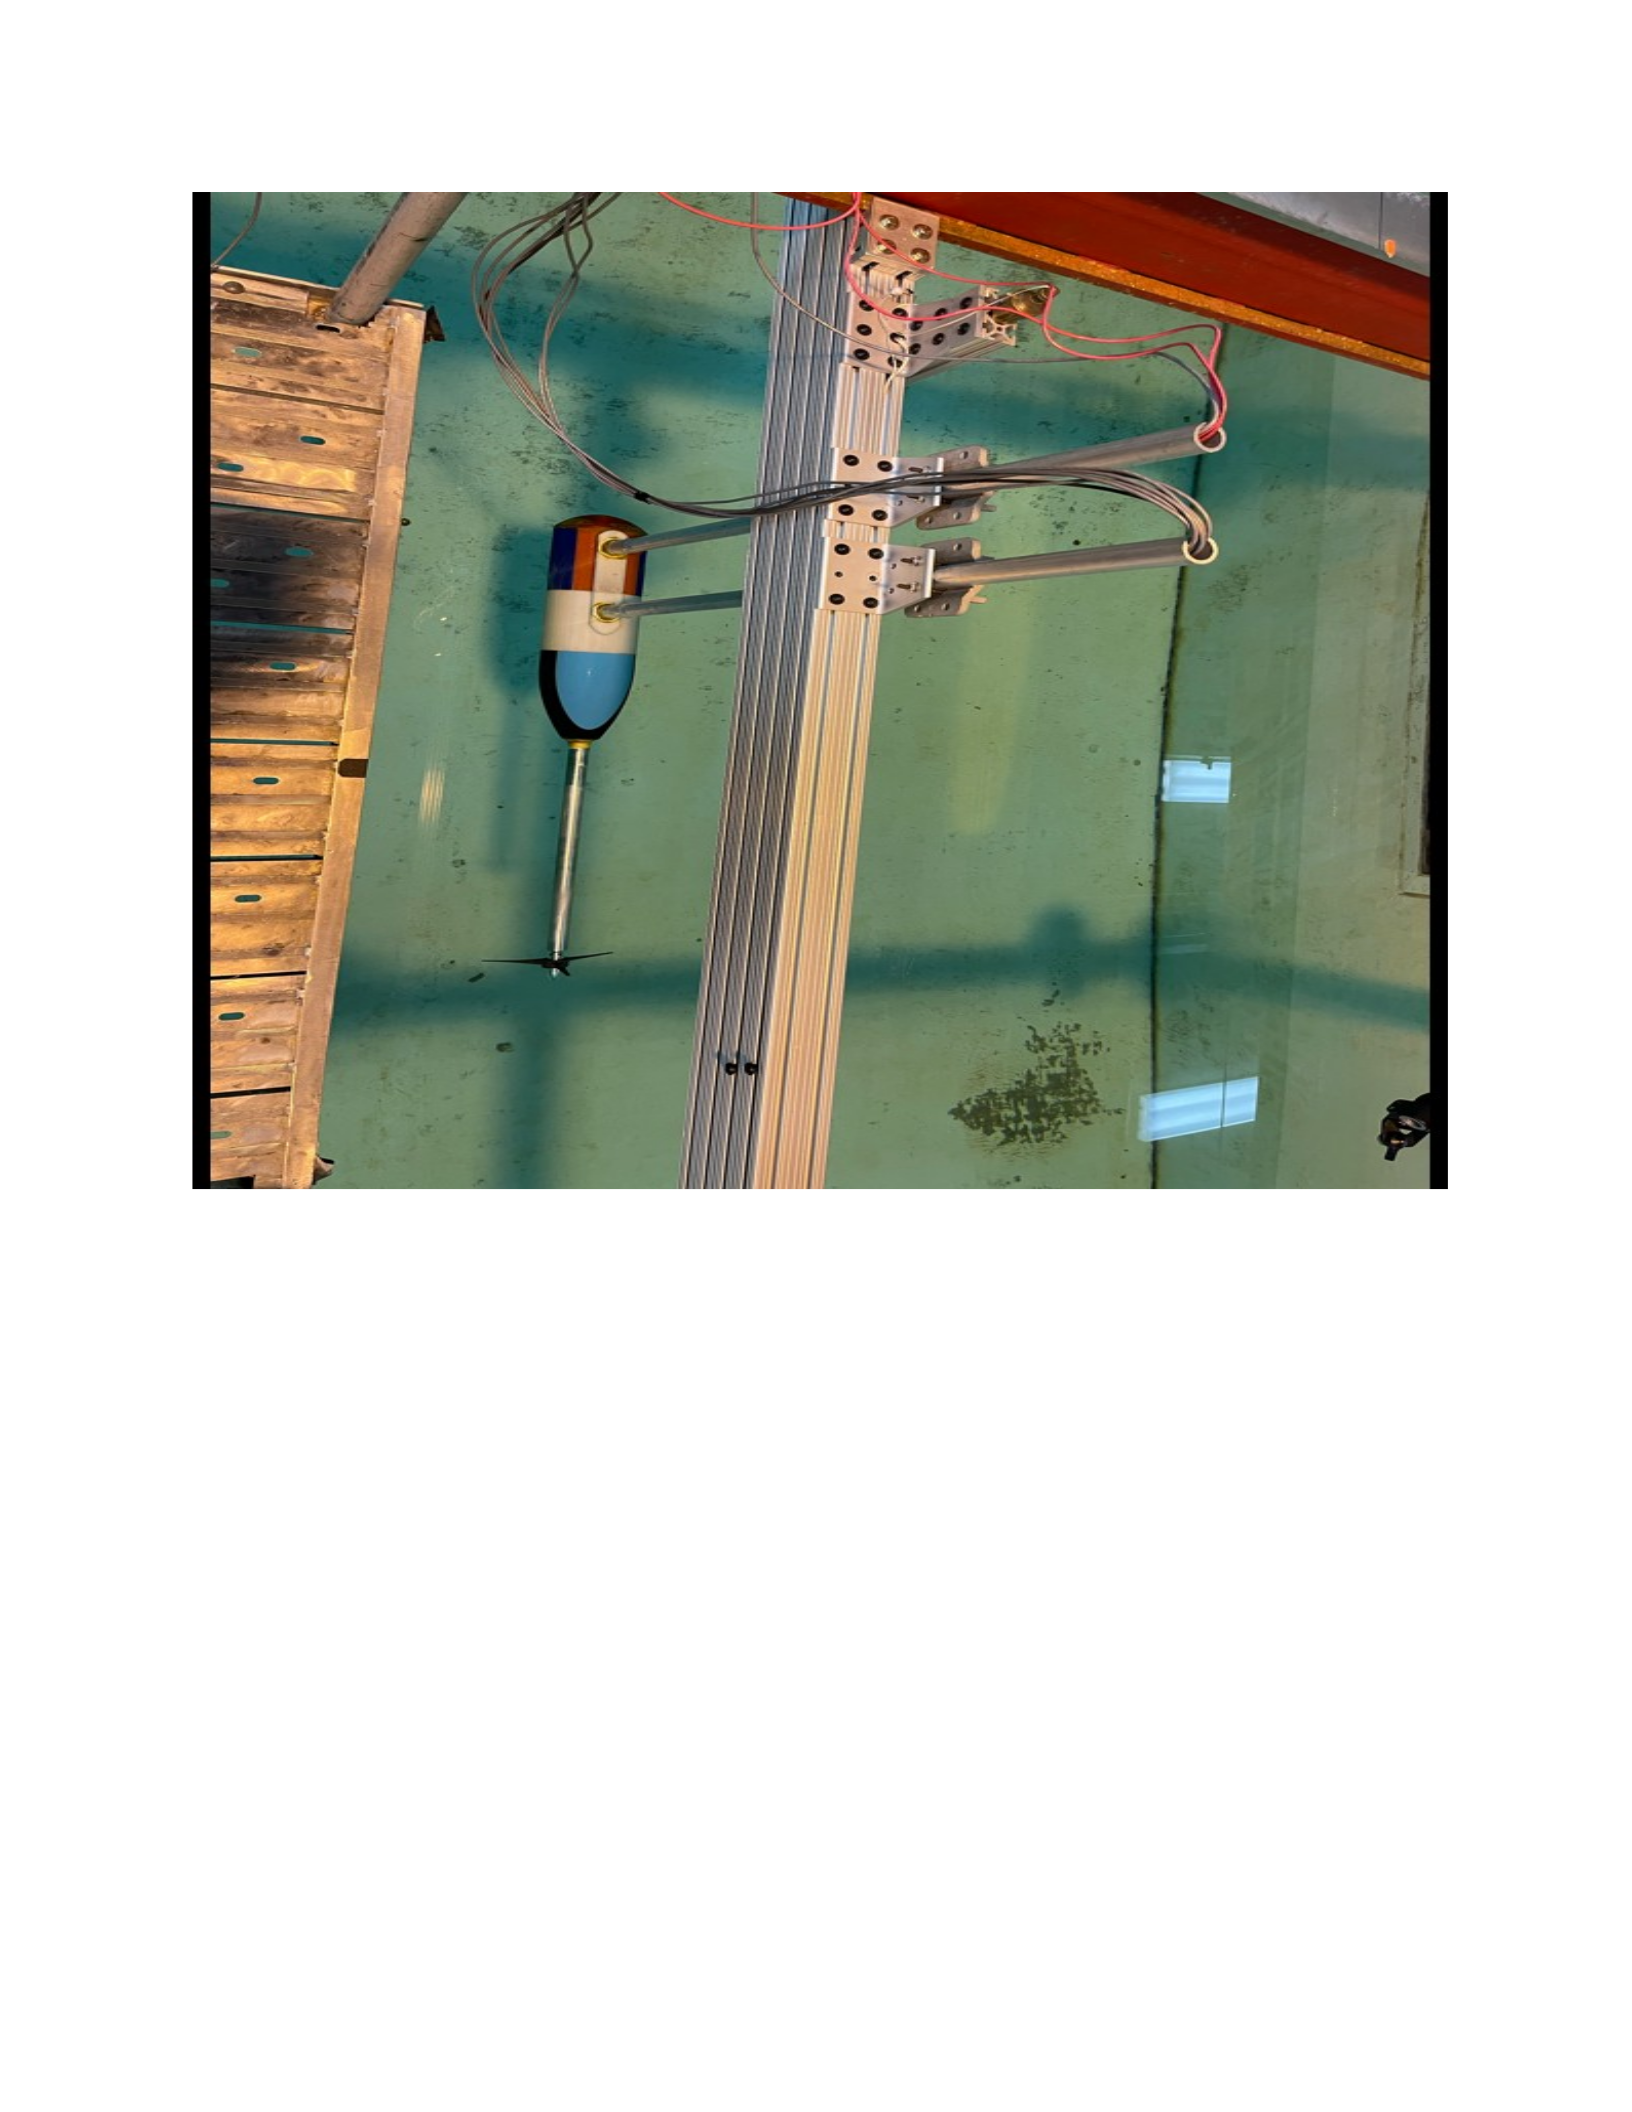
53
Figure 3.9 Installed Turbine
Figures 3.10 and 3.11 illustrate the installation of the OCT to the carriage in the UNO towing
tank facility from different views.
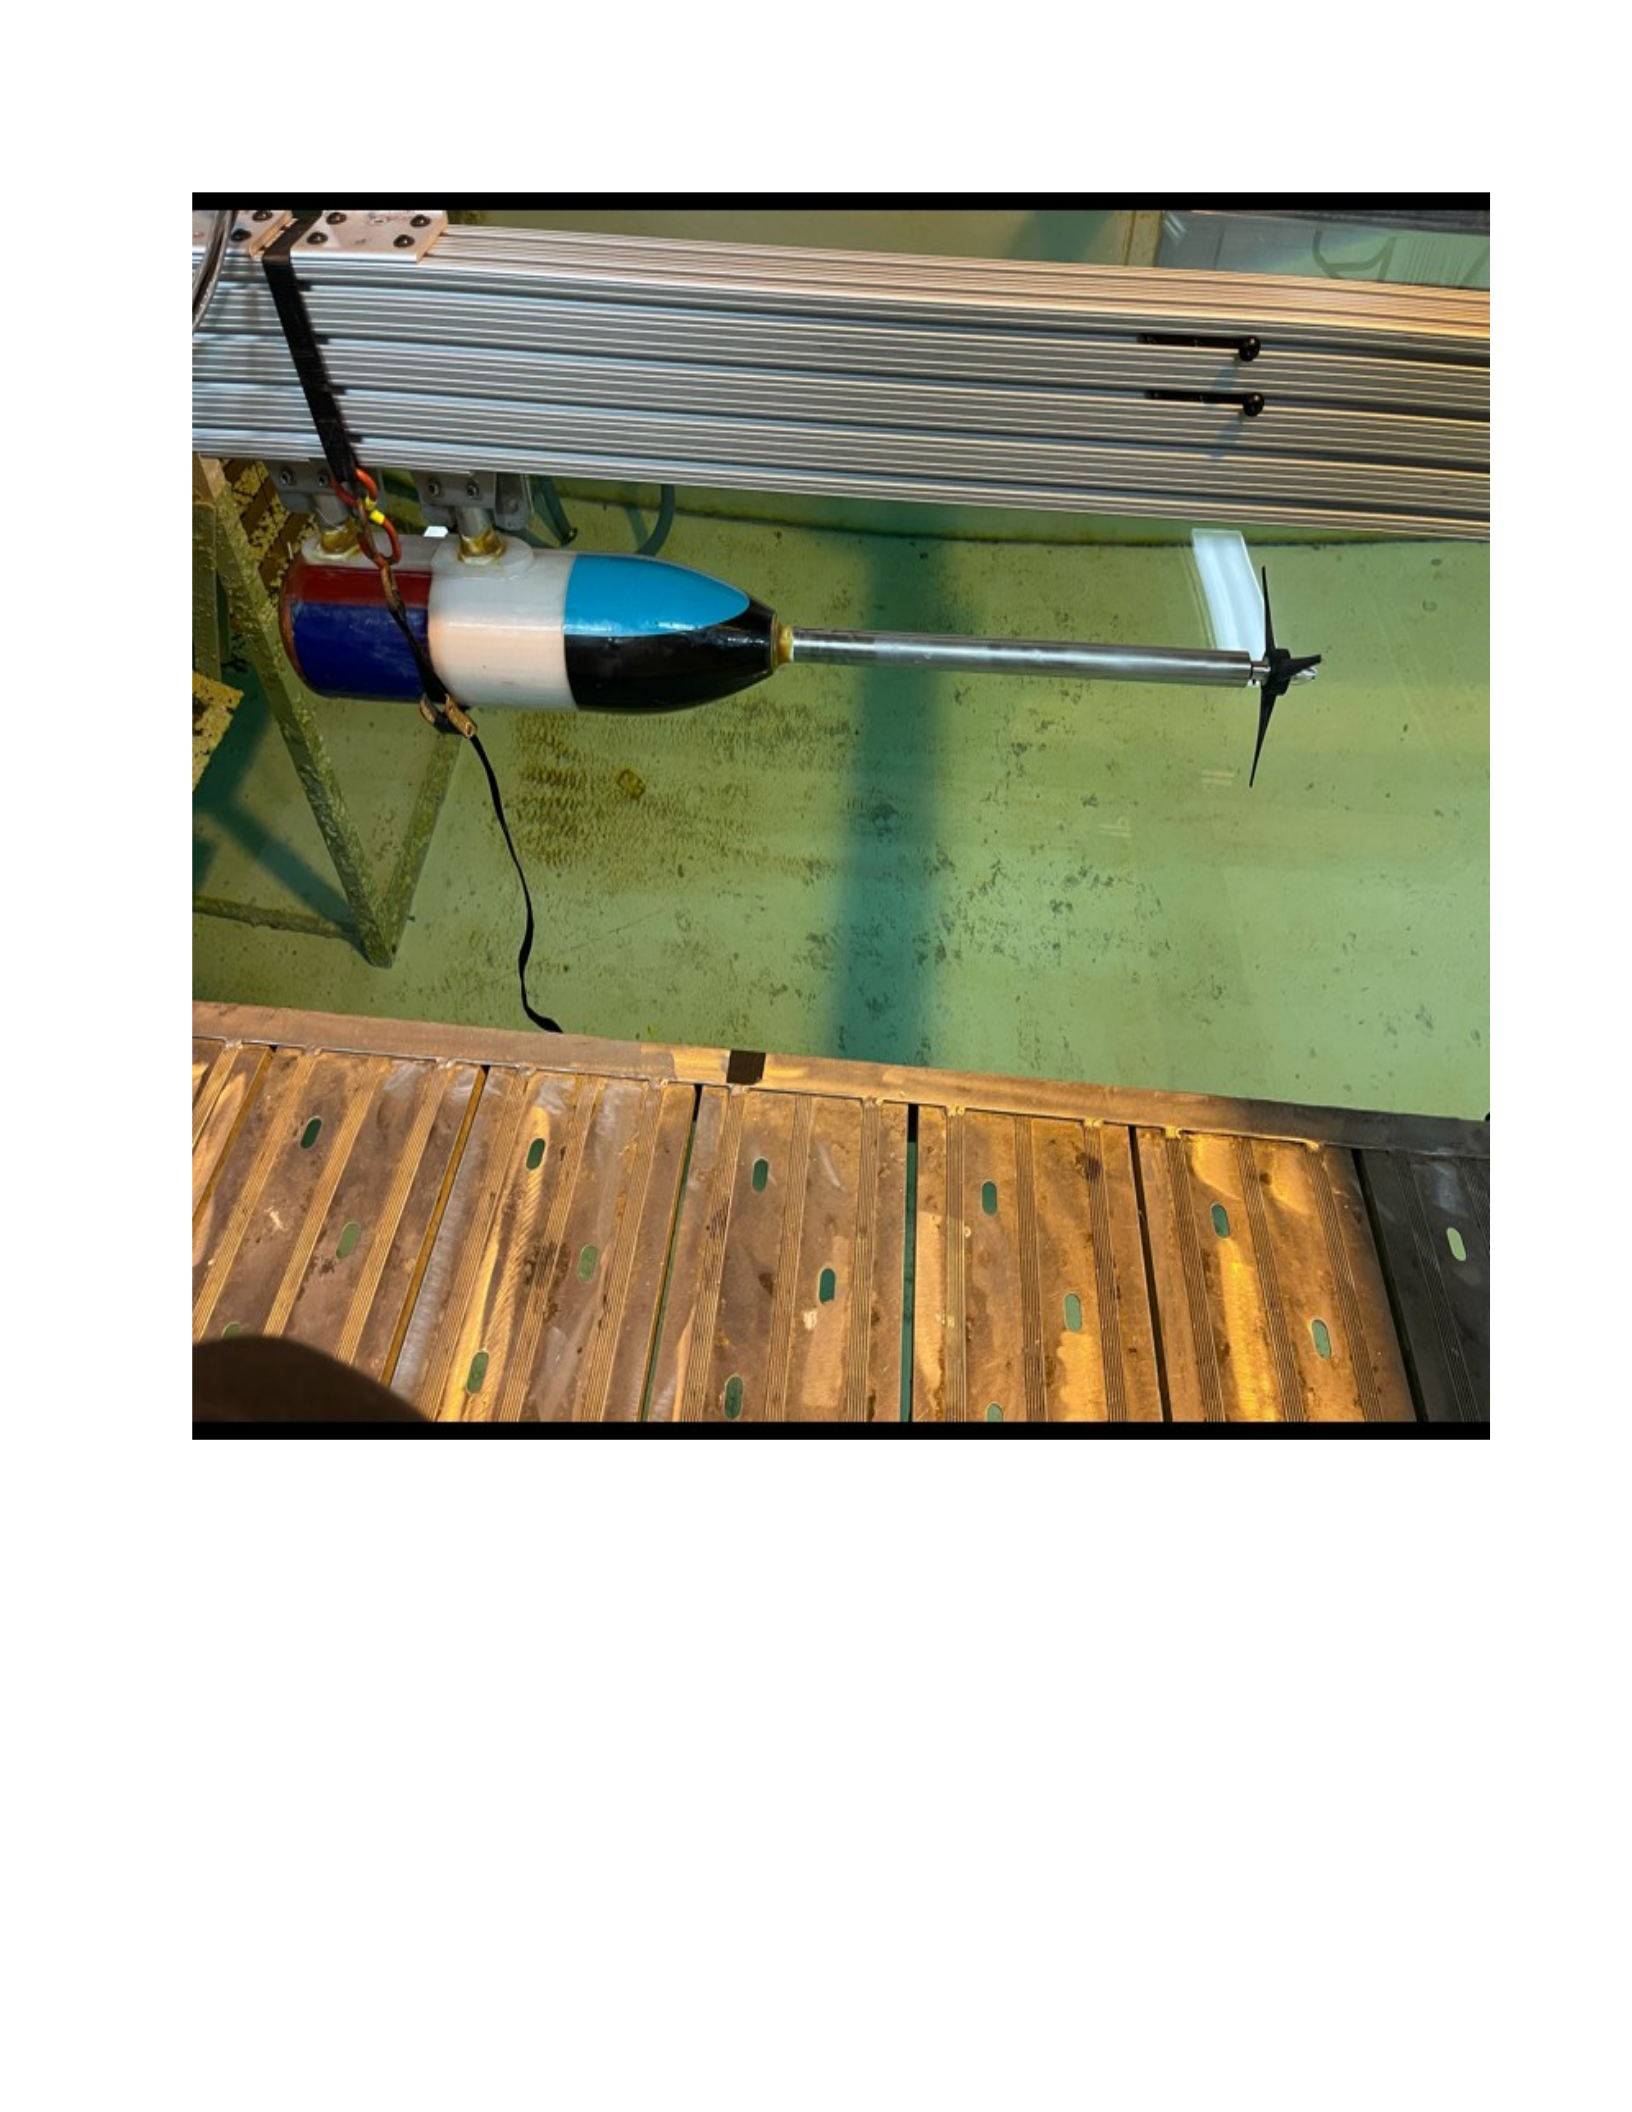
54
Figure 3.11 Installed Turbine from another View
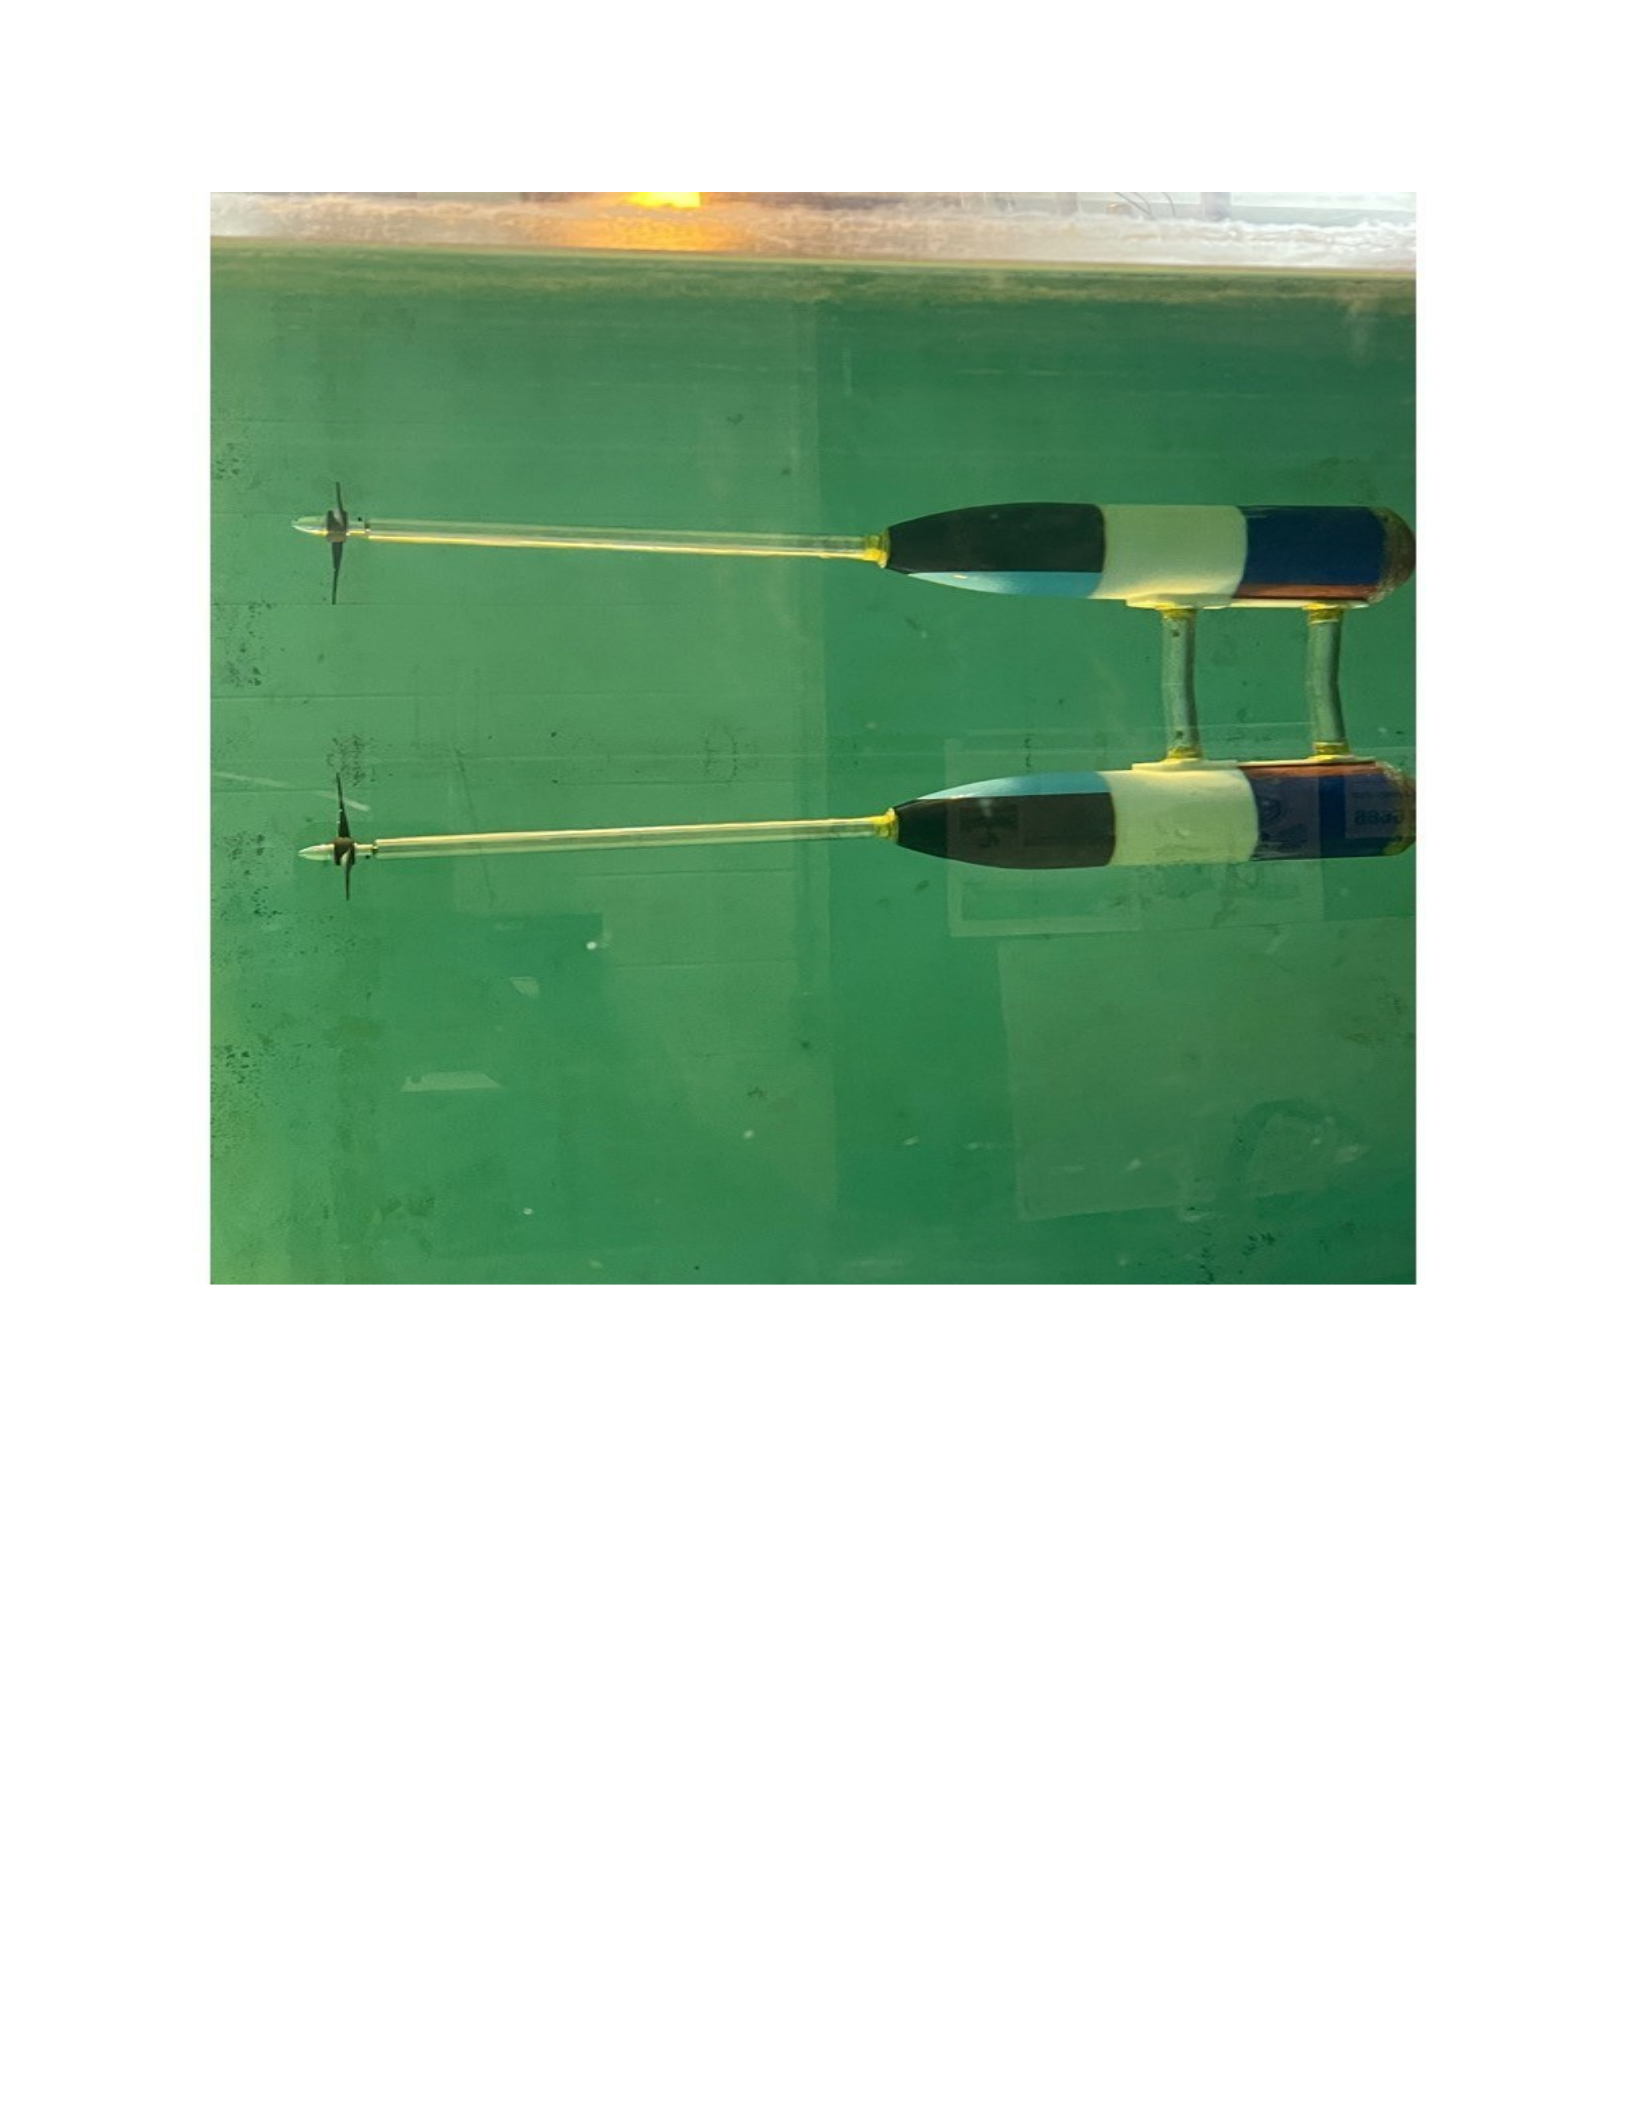
55
Figure 3.12 Reflection of a Turbine in Water
Figure 3.12 shows the OCT while underwater before performing the test. This design was one
of our first designs before the final test and it worked.
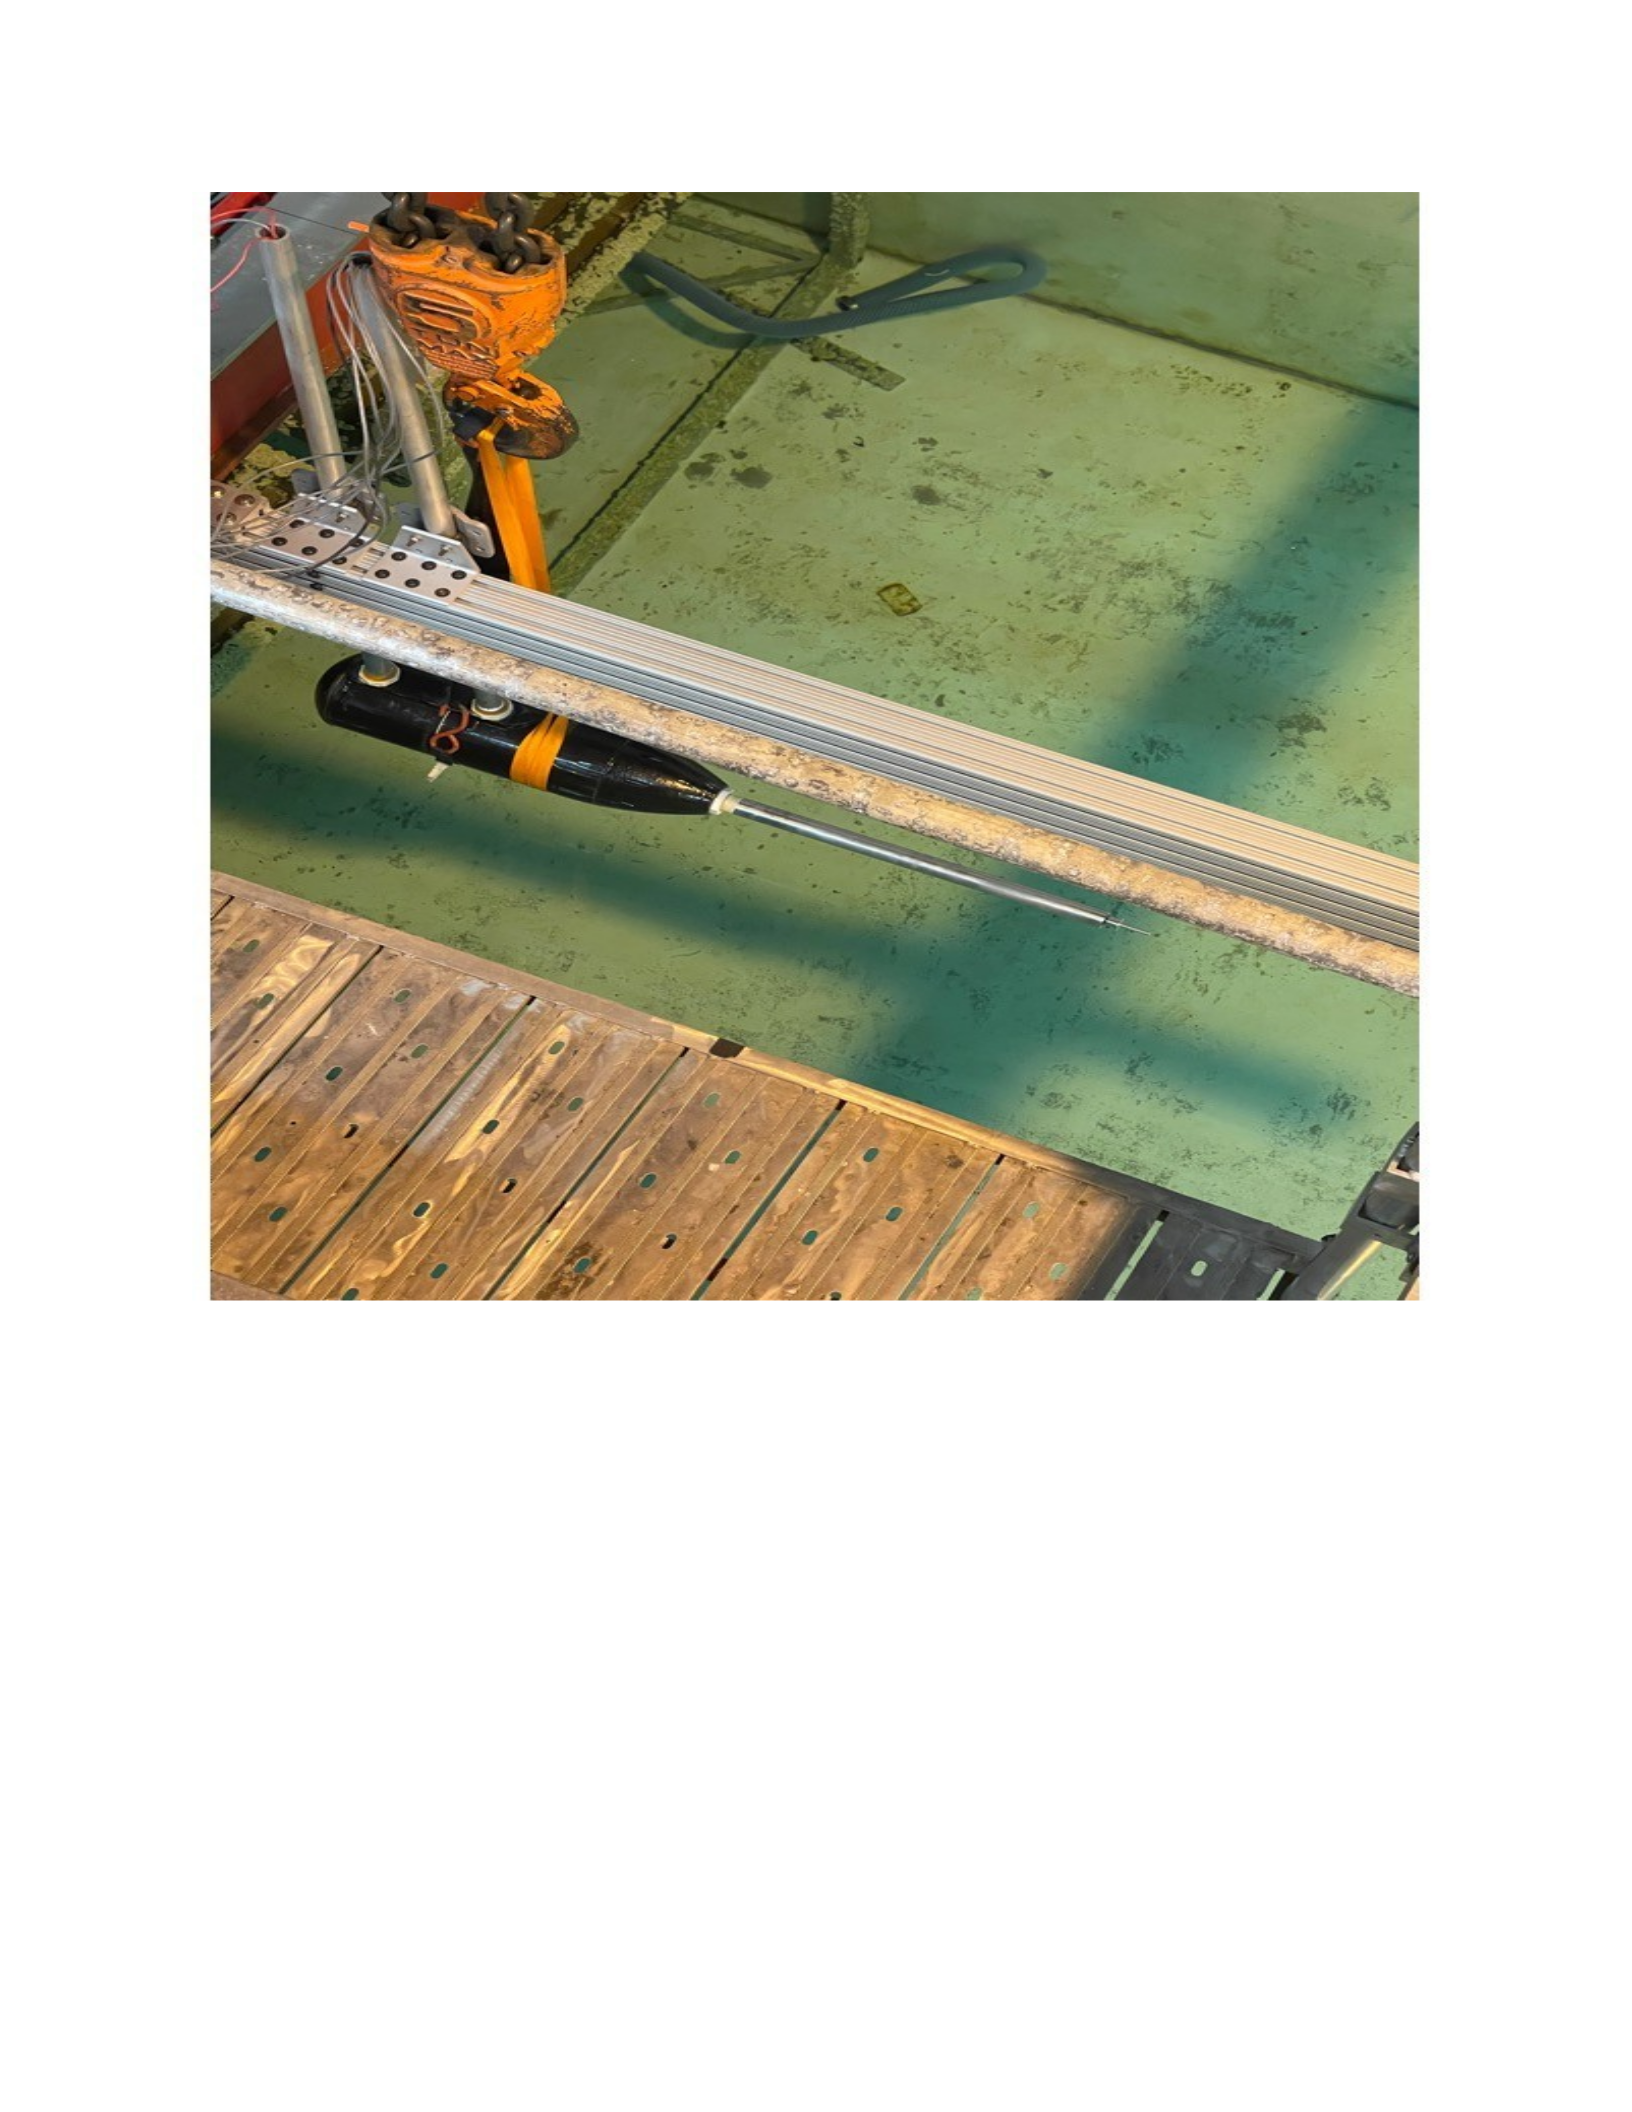
56
Figure 3.13 Installation of the New Generation Nacelle
Figure 3.13 shows the final design by utilizing a magnetic coupling before installing the
propeller.
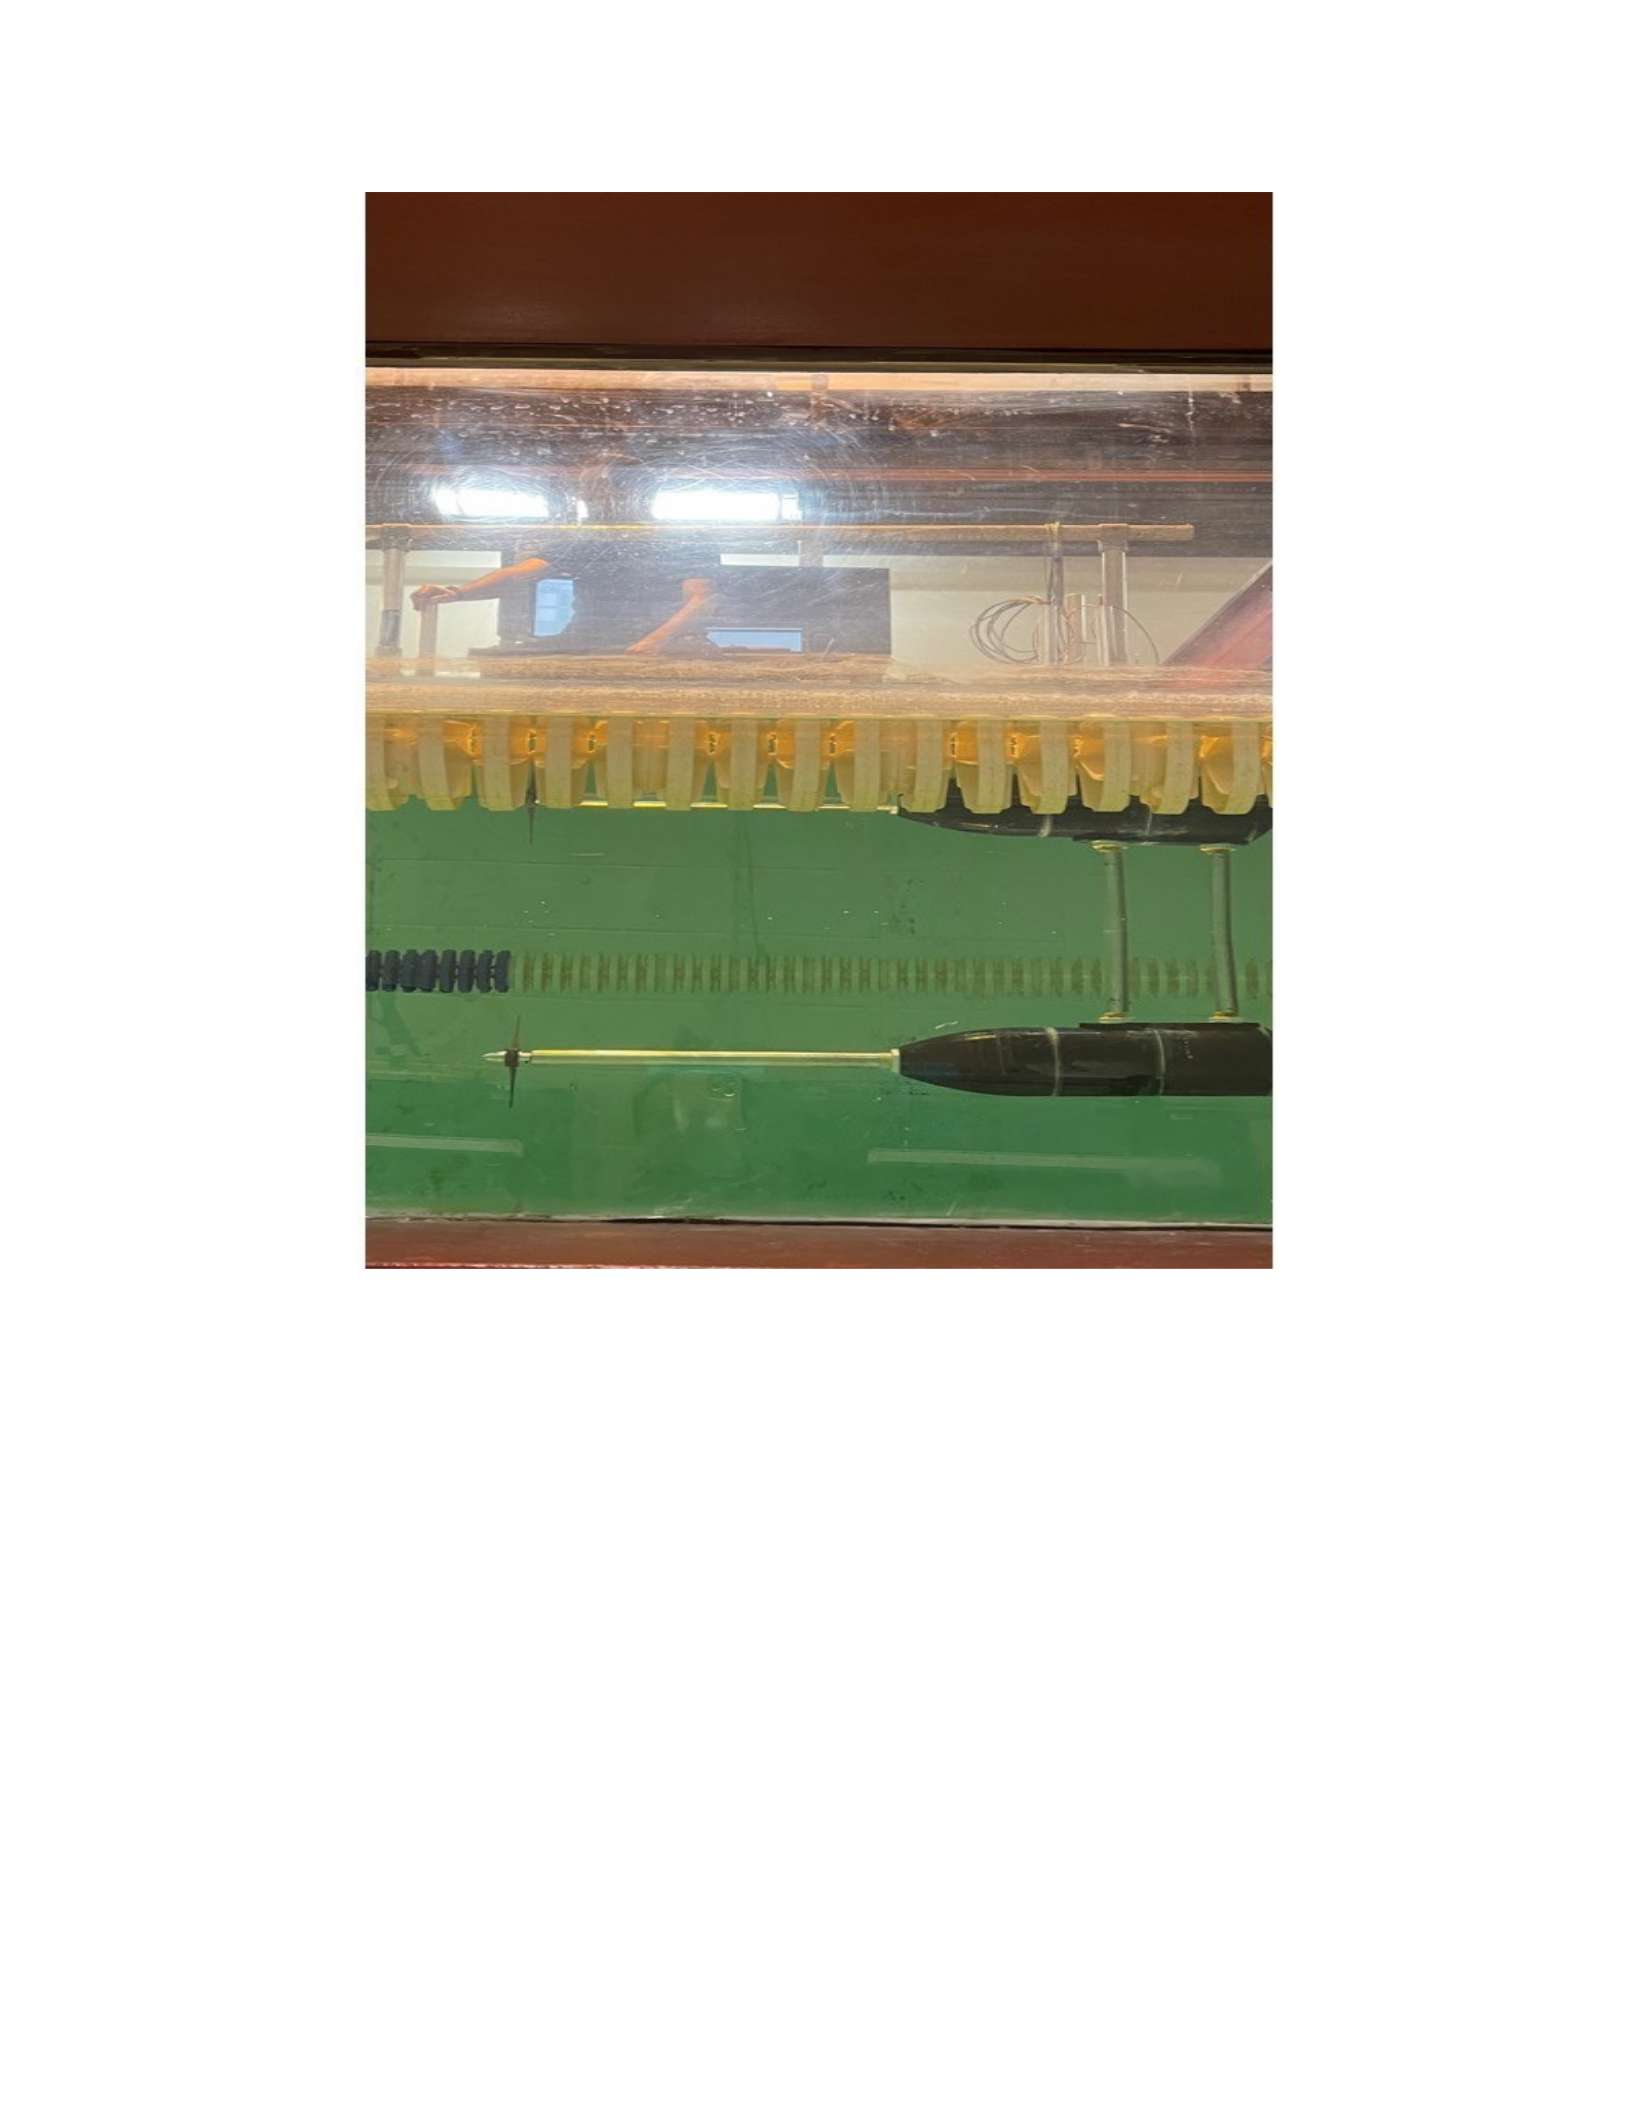
57
Figure 3.14 New Generation Turbine
Figure 3.14 shows the final design by utilizing a magnetic coupling after installing the propeller.
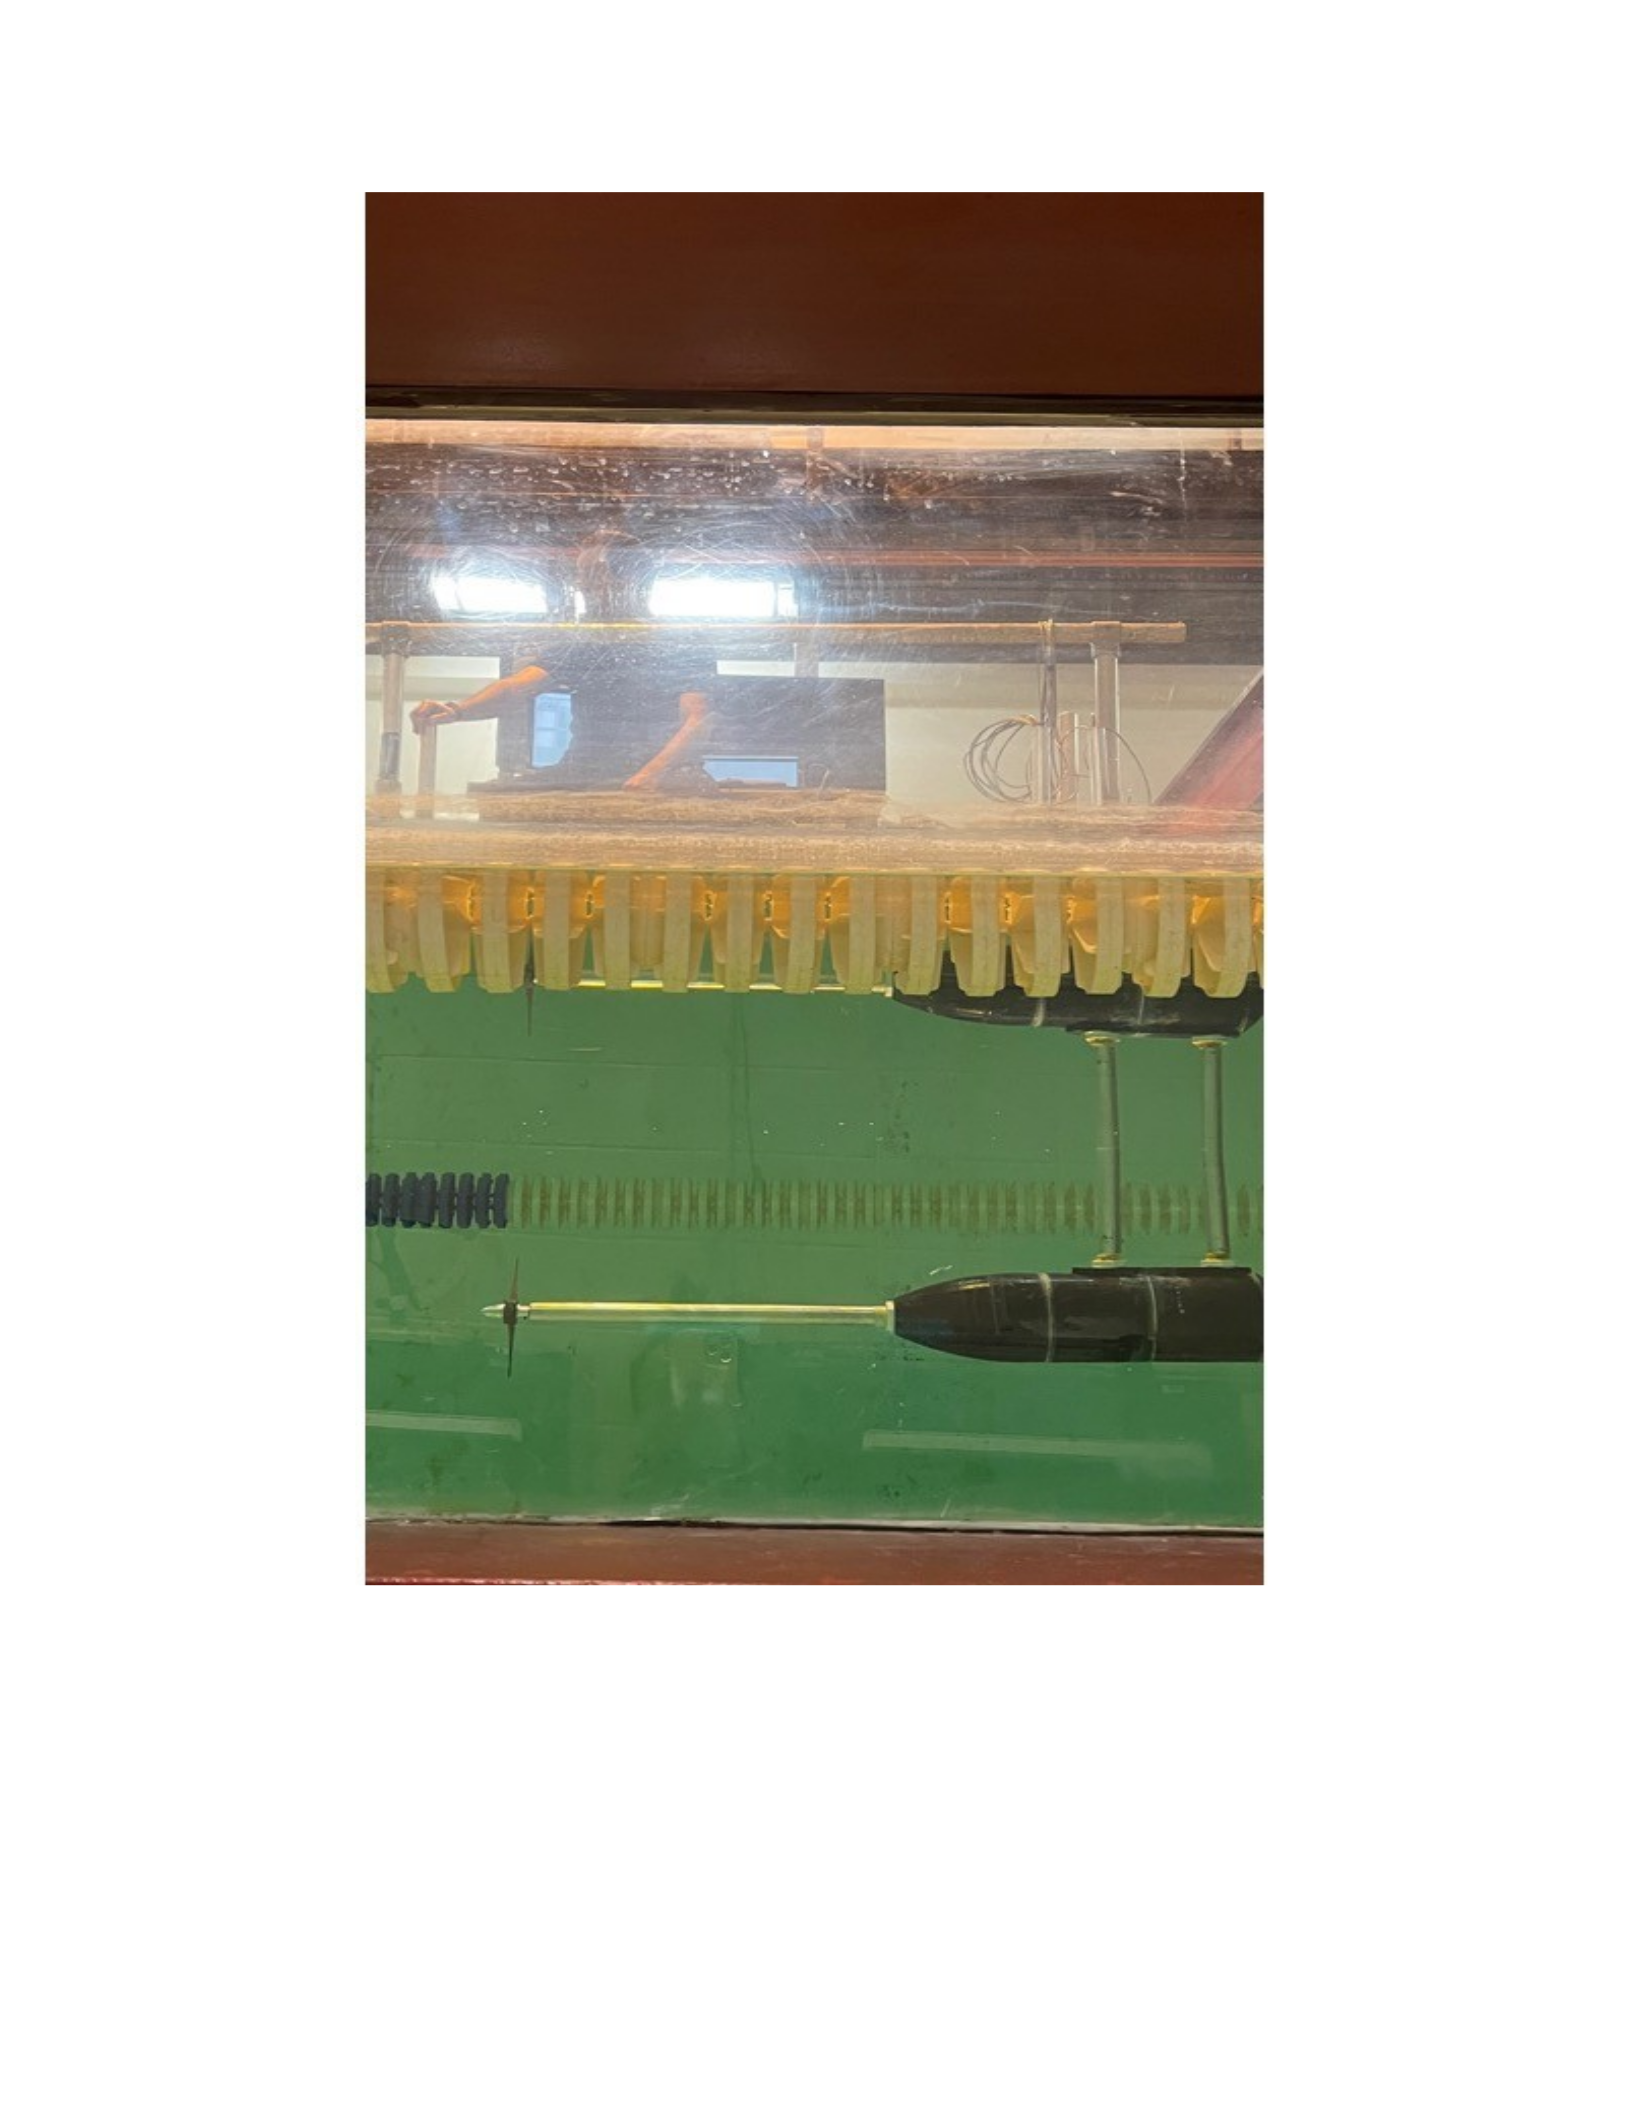
58
Figure 3.15 New Generation Turbine in Action
Figure 3.15 shows the final design utilizing a magnetic clutch after installing the propeller while
the OCT is running underwater.
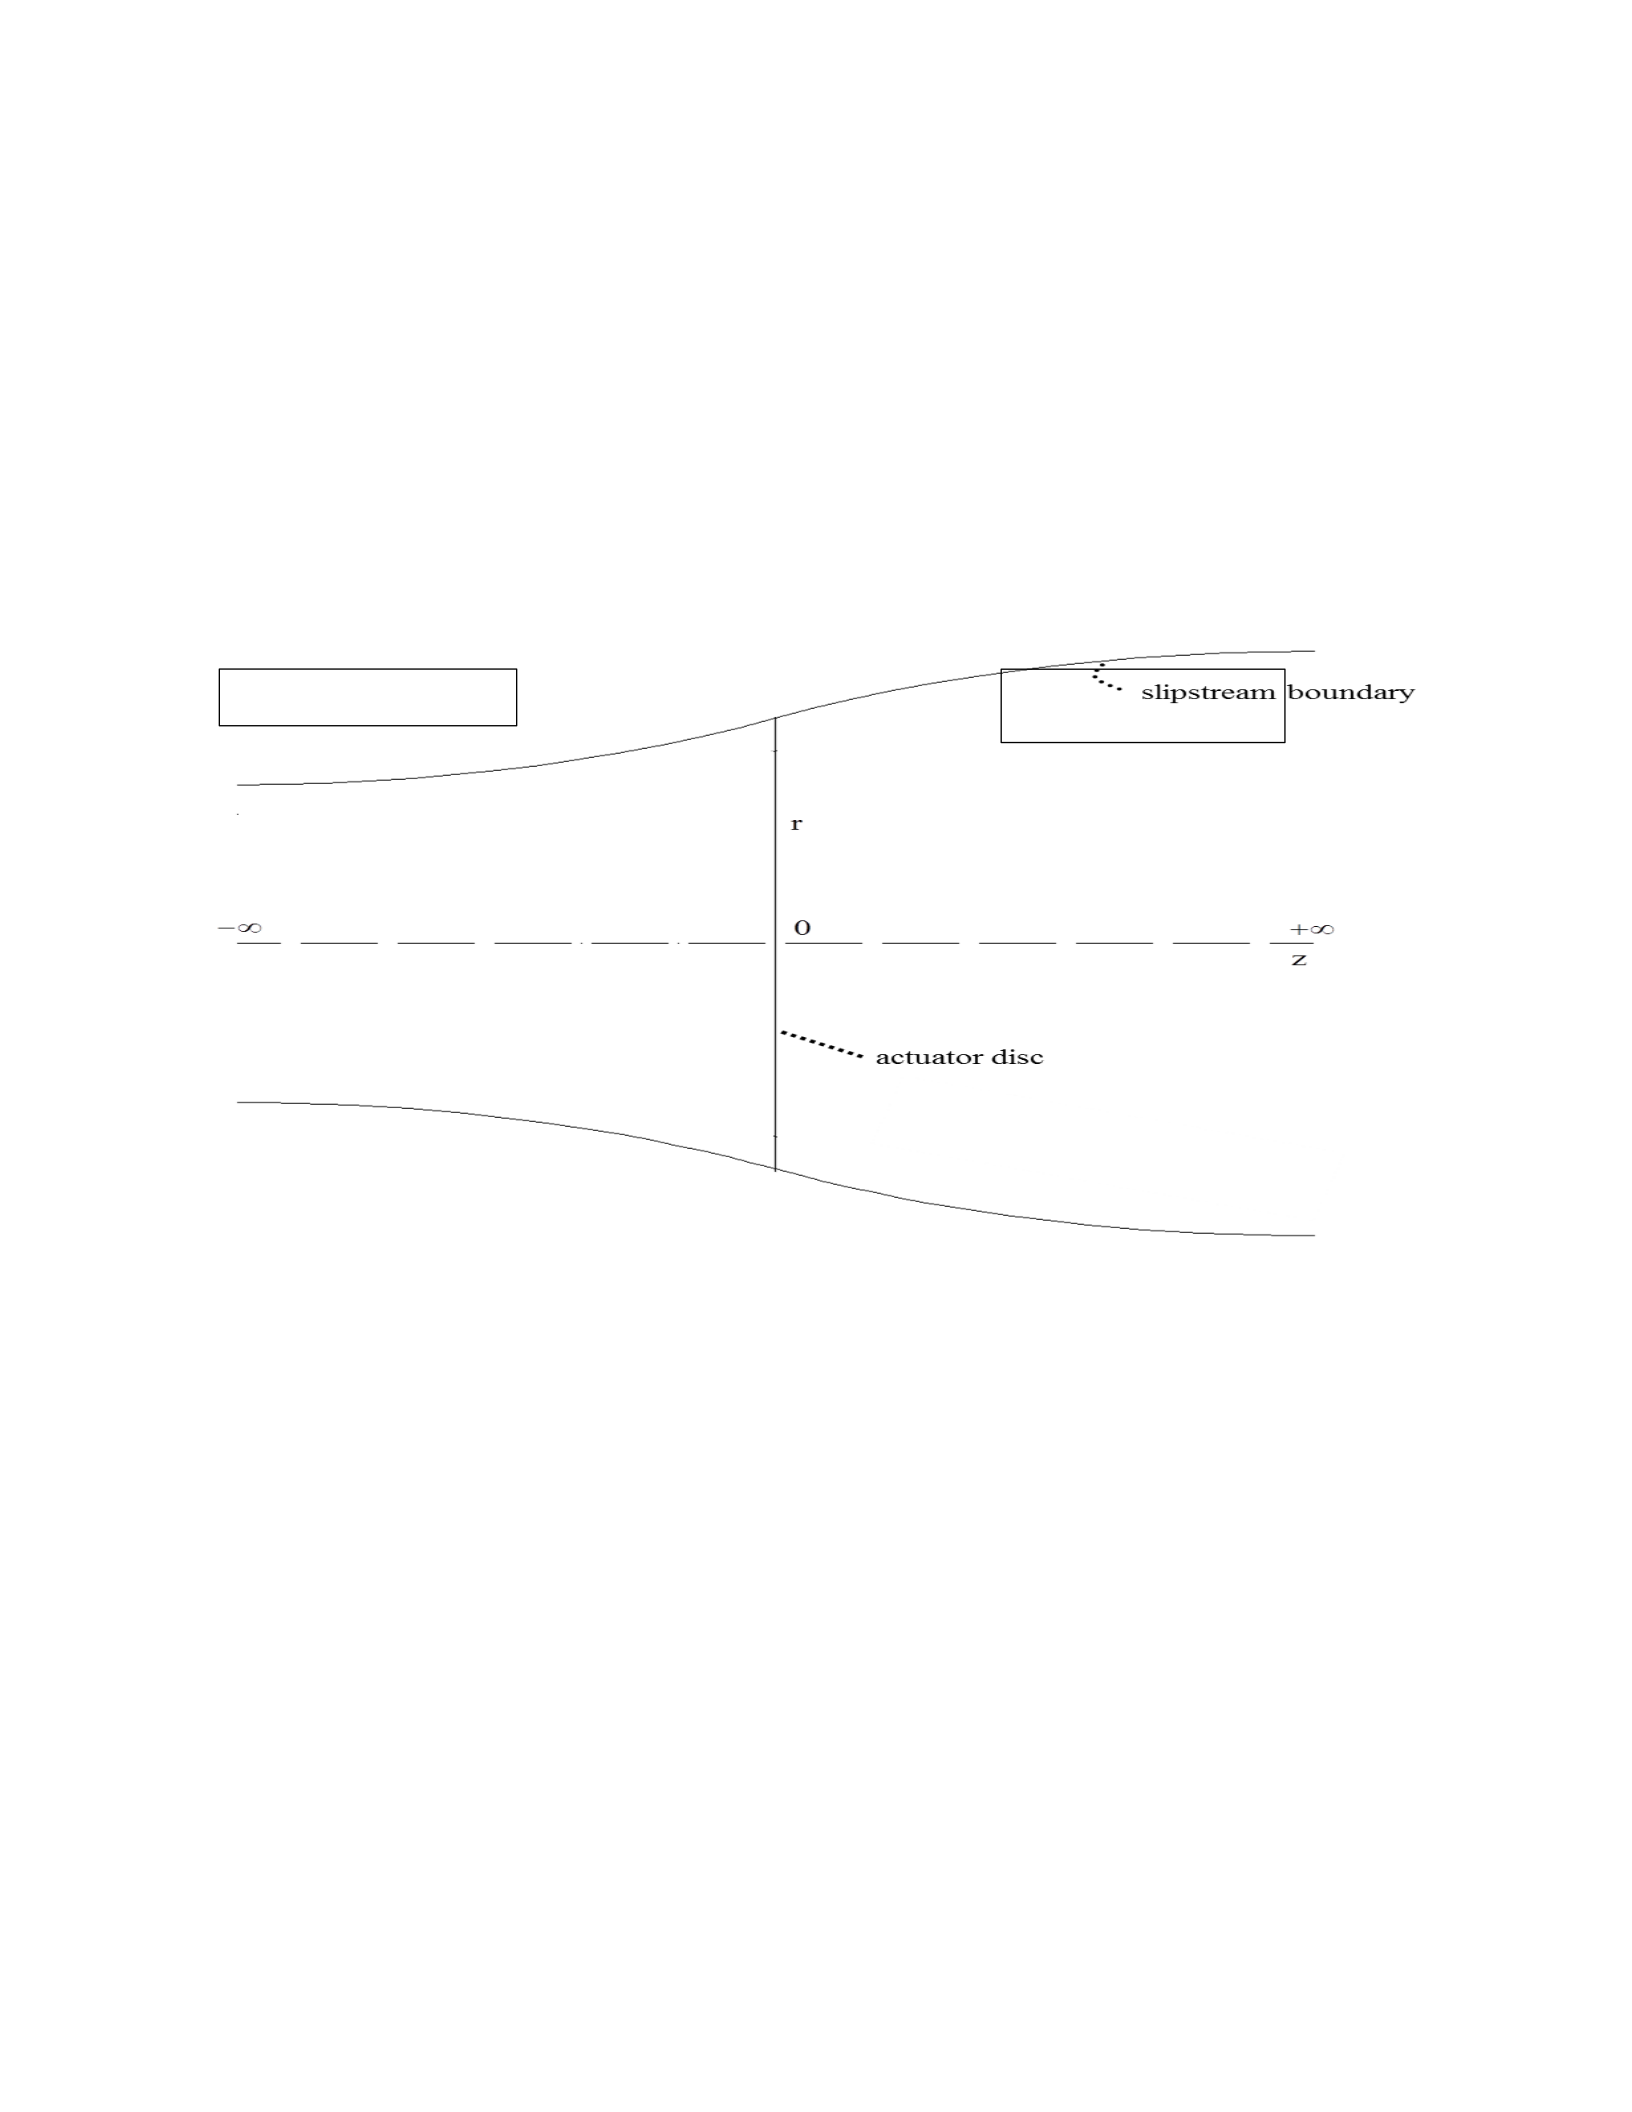
59
Chapter 4: Theory of Momentum of the Blade Element
4.1 ACTUATOR DISC CONCEPT
Froude presented the classical theory of momentum by assuming that the flow is non-kinetic,
incompressible, non-rotating, and that the velocity and pressure are uniform.
FIGURE 4.1: ACTUATOR DISC AND FLOW TUBE.
For the sake of simplicity, let's start by replacing the actuator disc with OCT in seawater to
collect kinetic energy before taking into account the unique design characteristics of the turbine.
Assume that, as illustrated in figure 4.1, downstream has a larger cross-sectional area in the
channel and upstream has a lower cross-sectional area than the actuator disc. The amount of
water flowing through the channel at a specified cross-section is equal to the AU. Taking into
account the principles of mass conservation:
ρA∞U∞ = ρAdUd =
A
)
𝑈
)
(4.1)
P
+
�
�
Ye
s!
Ite
m∞
U
w
U
dIte
m
∞
P
−
�
�
Wake upUpstream
60
The upstream (current velocity), actuator disc, and downstream conditions are indicated by
subscripts, d and w. Due to the axial induction factor of the actuator disc, a, which causes some
𝑈𝑑 = 𝑈∞(1 − a)(4.2)
𝑈
)
= U
∞
(1 − 2a)(4.3)
We must also take into account the tangential flow induction factor a( by considering the
tangential velocity in addition to the axial velocity. The zero tangential velocity is present in the
upstream, 2Ωra ( tangential velocity is present near the actuator disc downstream), and Ωra (
tangential velocity is present in the wake.
4.2 BLADE ELEMENT MOMENTUM THEORY
Blade Element Momentum (BEM) theory is a fundamental and widely used method for
predicting the performance of wind turbines and turbines today. It is based on a combination of
Blade Element Theory and Momentum Theory, integrating their principles to analyze the
aerodynamic forces acting on each segment of the rotor blade. Blade Element Theory is a
concept used to analyze the hydrodynamics of rotating blades. This divides the length of each
rotor blade into small segments (Blade elements). This theory considers each blade element to
be a separate hydrofoil, and the hydrodynamic forces acting on each element are calculated
separately, including the lift and tensile forces, which are perpendicular and parallel to the
direction of the relative fluid, respectively. This force is determined by the local angle of attack
and other factors, such as the hydrofoil pitch angle, shape, and rotation speed.
Momentum Theory, on the other hand, is a simple approach used to analyze the overall
hydrodynamic performance of an entire rotor or turbine. It is based on the principle of
conservation of momentum and assumes that the rotor disc acts as a single actuator disc that
accelerates and deflects the incoming flow. According to Momentum Theory, the rotor extracts
kinetic energy from the incoming fluid and converts it into mechanical energy, resulting in a
change in velocity and direction of flow downstream of the rotor. This theory allows for the
calculation of the thrust and overall power produced by the rotor, providing valuable insights
into its performance.
Blade Element Momentum Theory combines the principles of Blade Element Theory and
Momentum Theory to provide a comprehensive and accurate analysis of the current
hydrodynamic performance of turbines. In this theory, the rotor disc is divided into blade
elements, and the hydrodynamic force on each element is calculated using the Blade Element
Theory.
The calculated hydrodynamic forces (Tensile and lift forces) are then integrated across the
rotor discs using Momentum Theory to determine the final thrust, power, and efficiency of the
rotor. Elemental Momentum Theory Blade takes into account the effects of wake effects, such
as induced velocity and downwash, which are not considered in Momentum Theory alone.
Let's replace the actuator disc with a 3-blade marine current turbine. As shown in figure 4.2, if
the theoretical net tangential velocity of the blade element is Ωr(1 + a()the resulting velocity is
then defined as
W = H[U∞(1 − a]2 + [Ωr(1 + a′)]2(4.4)
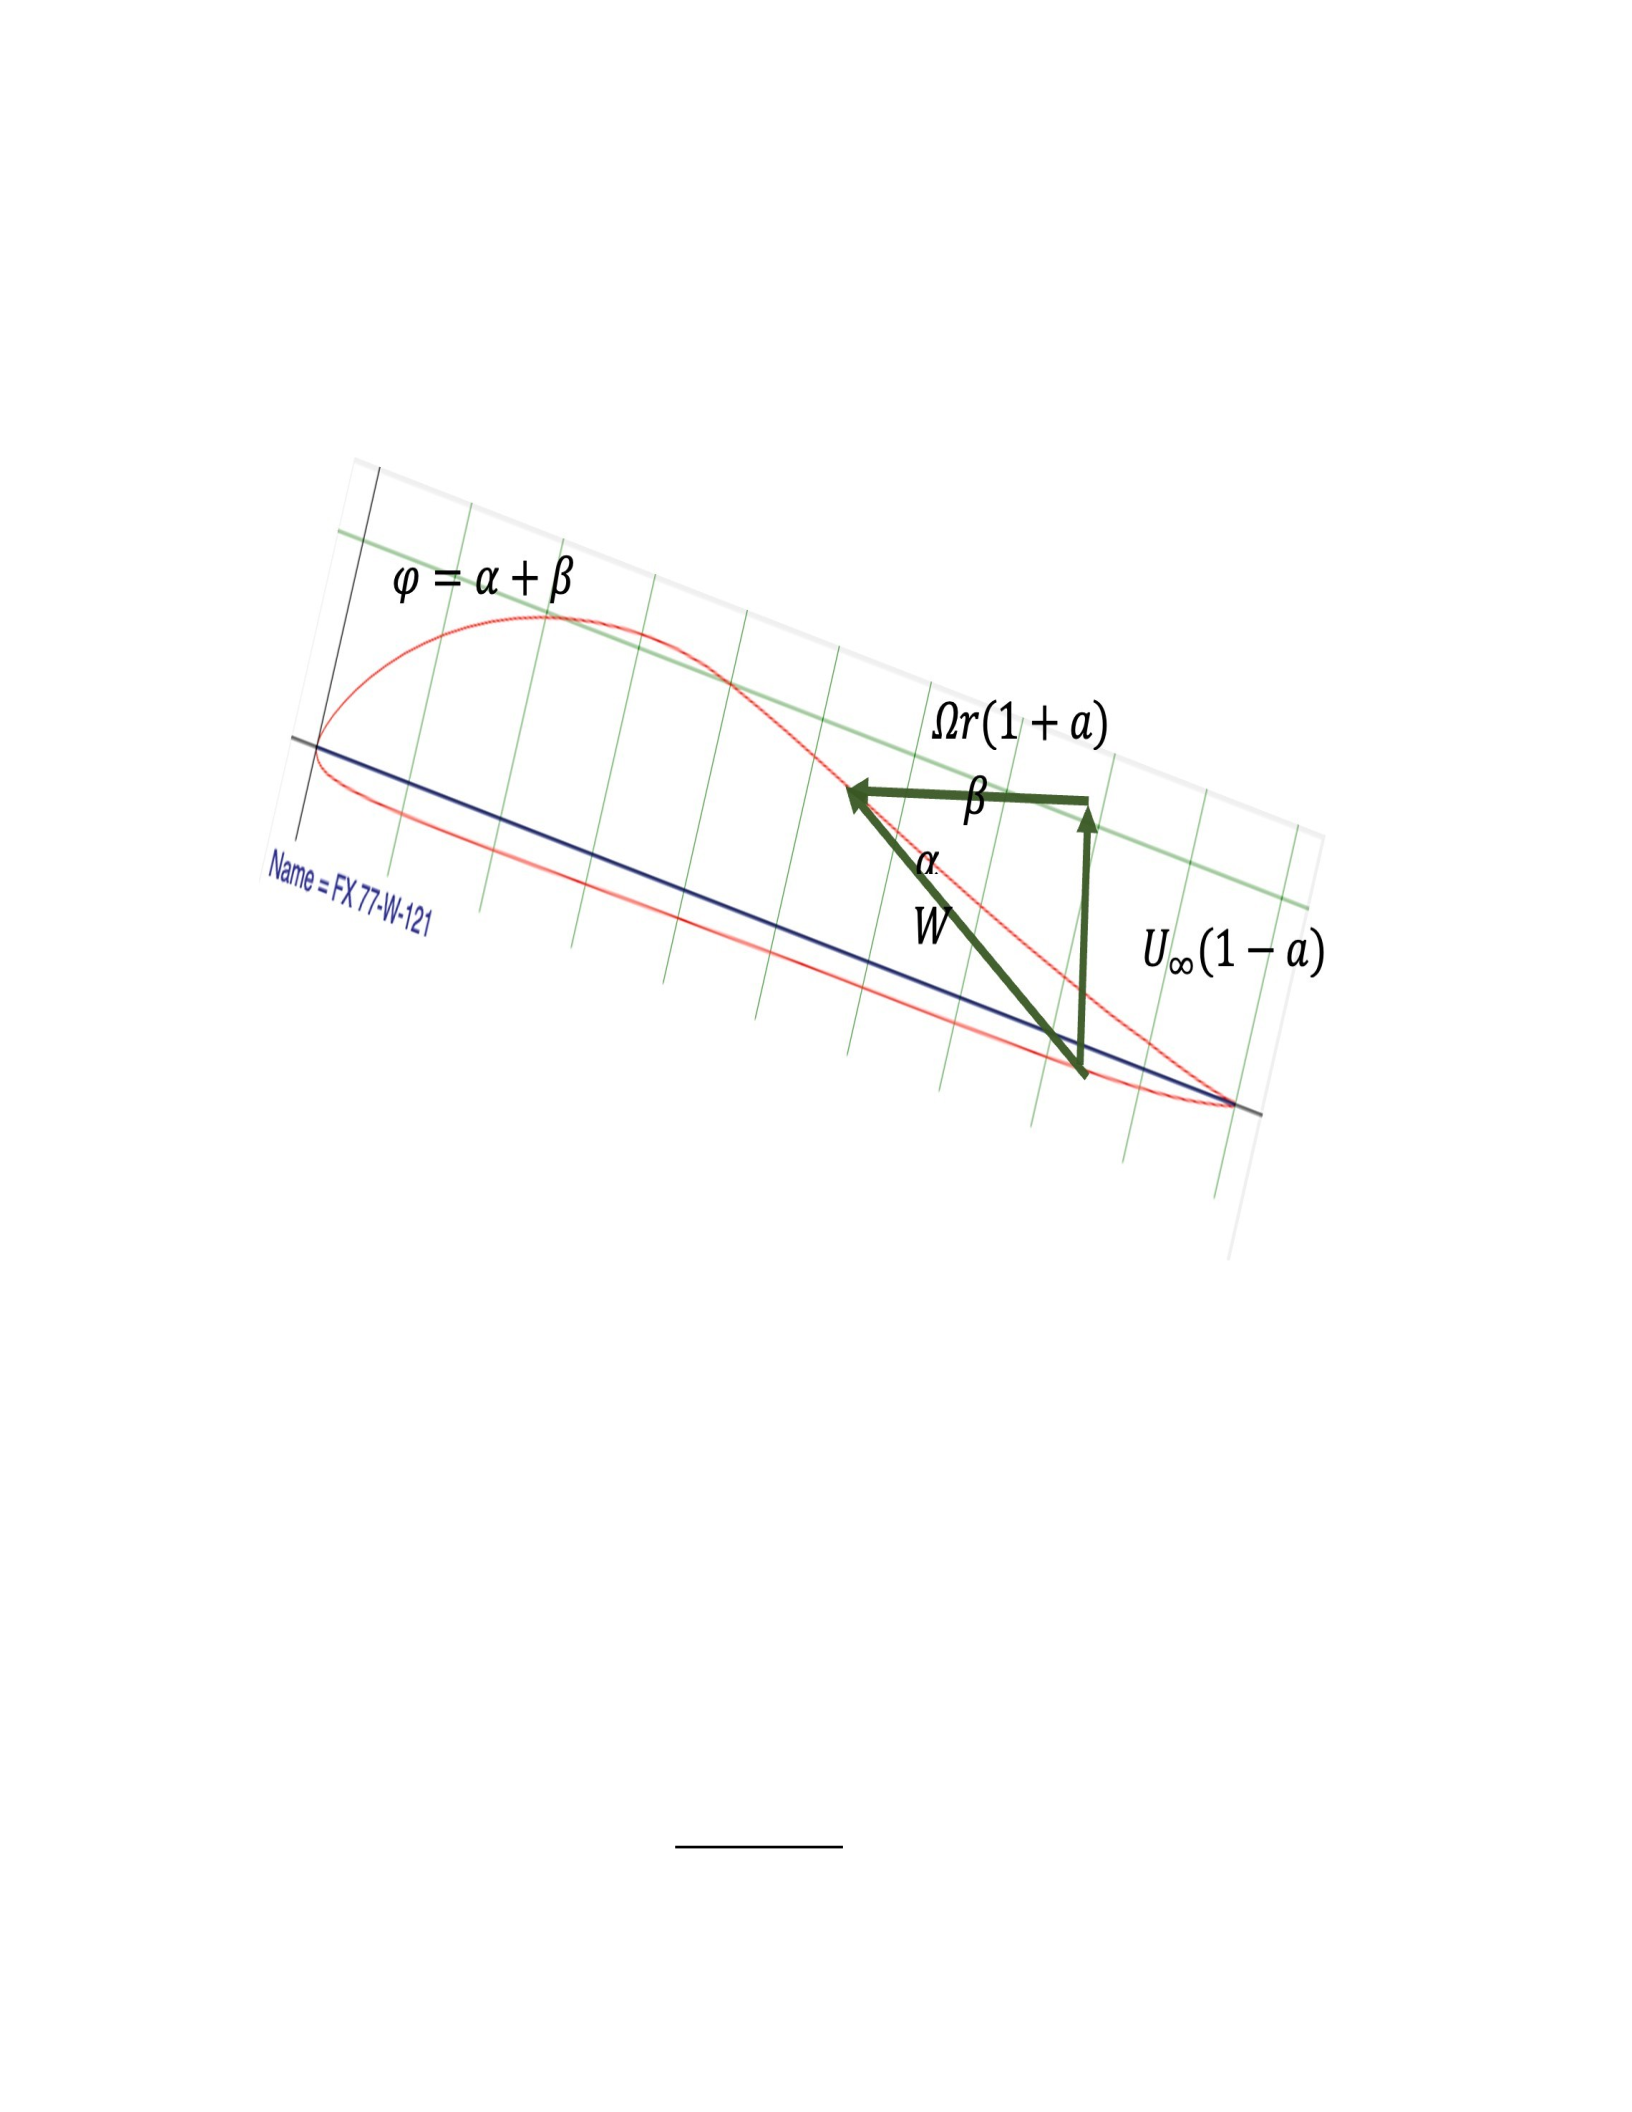
61
FIGURE 4.2: MOMENTUM BAND speed. (Airfoil FX 77-W-121 sketched by Airfoil
Tools)
Axial and tangential induction factors are generated by knowing how the aerodynamic lift
coefficients (Cl) and drag ( Cd) vary with respect to the angle of attack for each blade. Figure
7 illustrates the application of the law of conservation of momentum and energy with a single
OCT with an N bar and varying chord lengths and pitch angles for 25 different cross-sections.
dosa φ = U∞(1
− a) 𝑊(4.5)
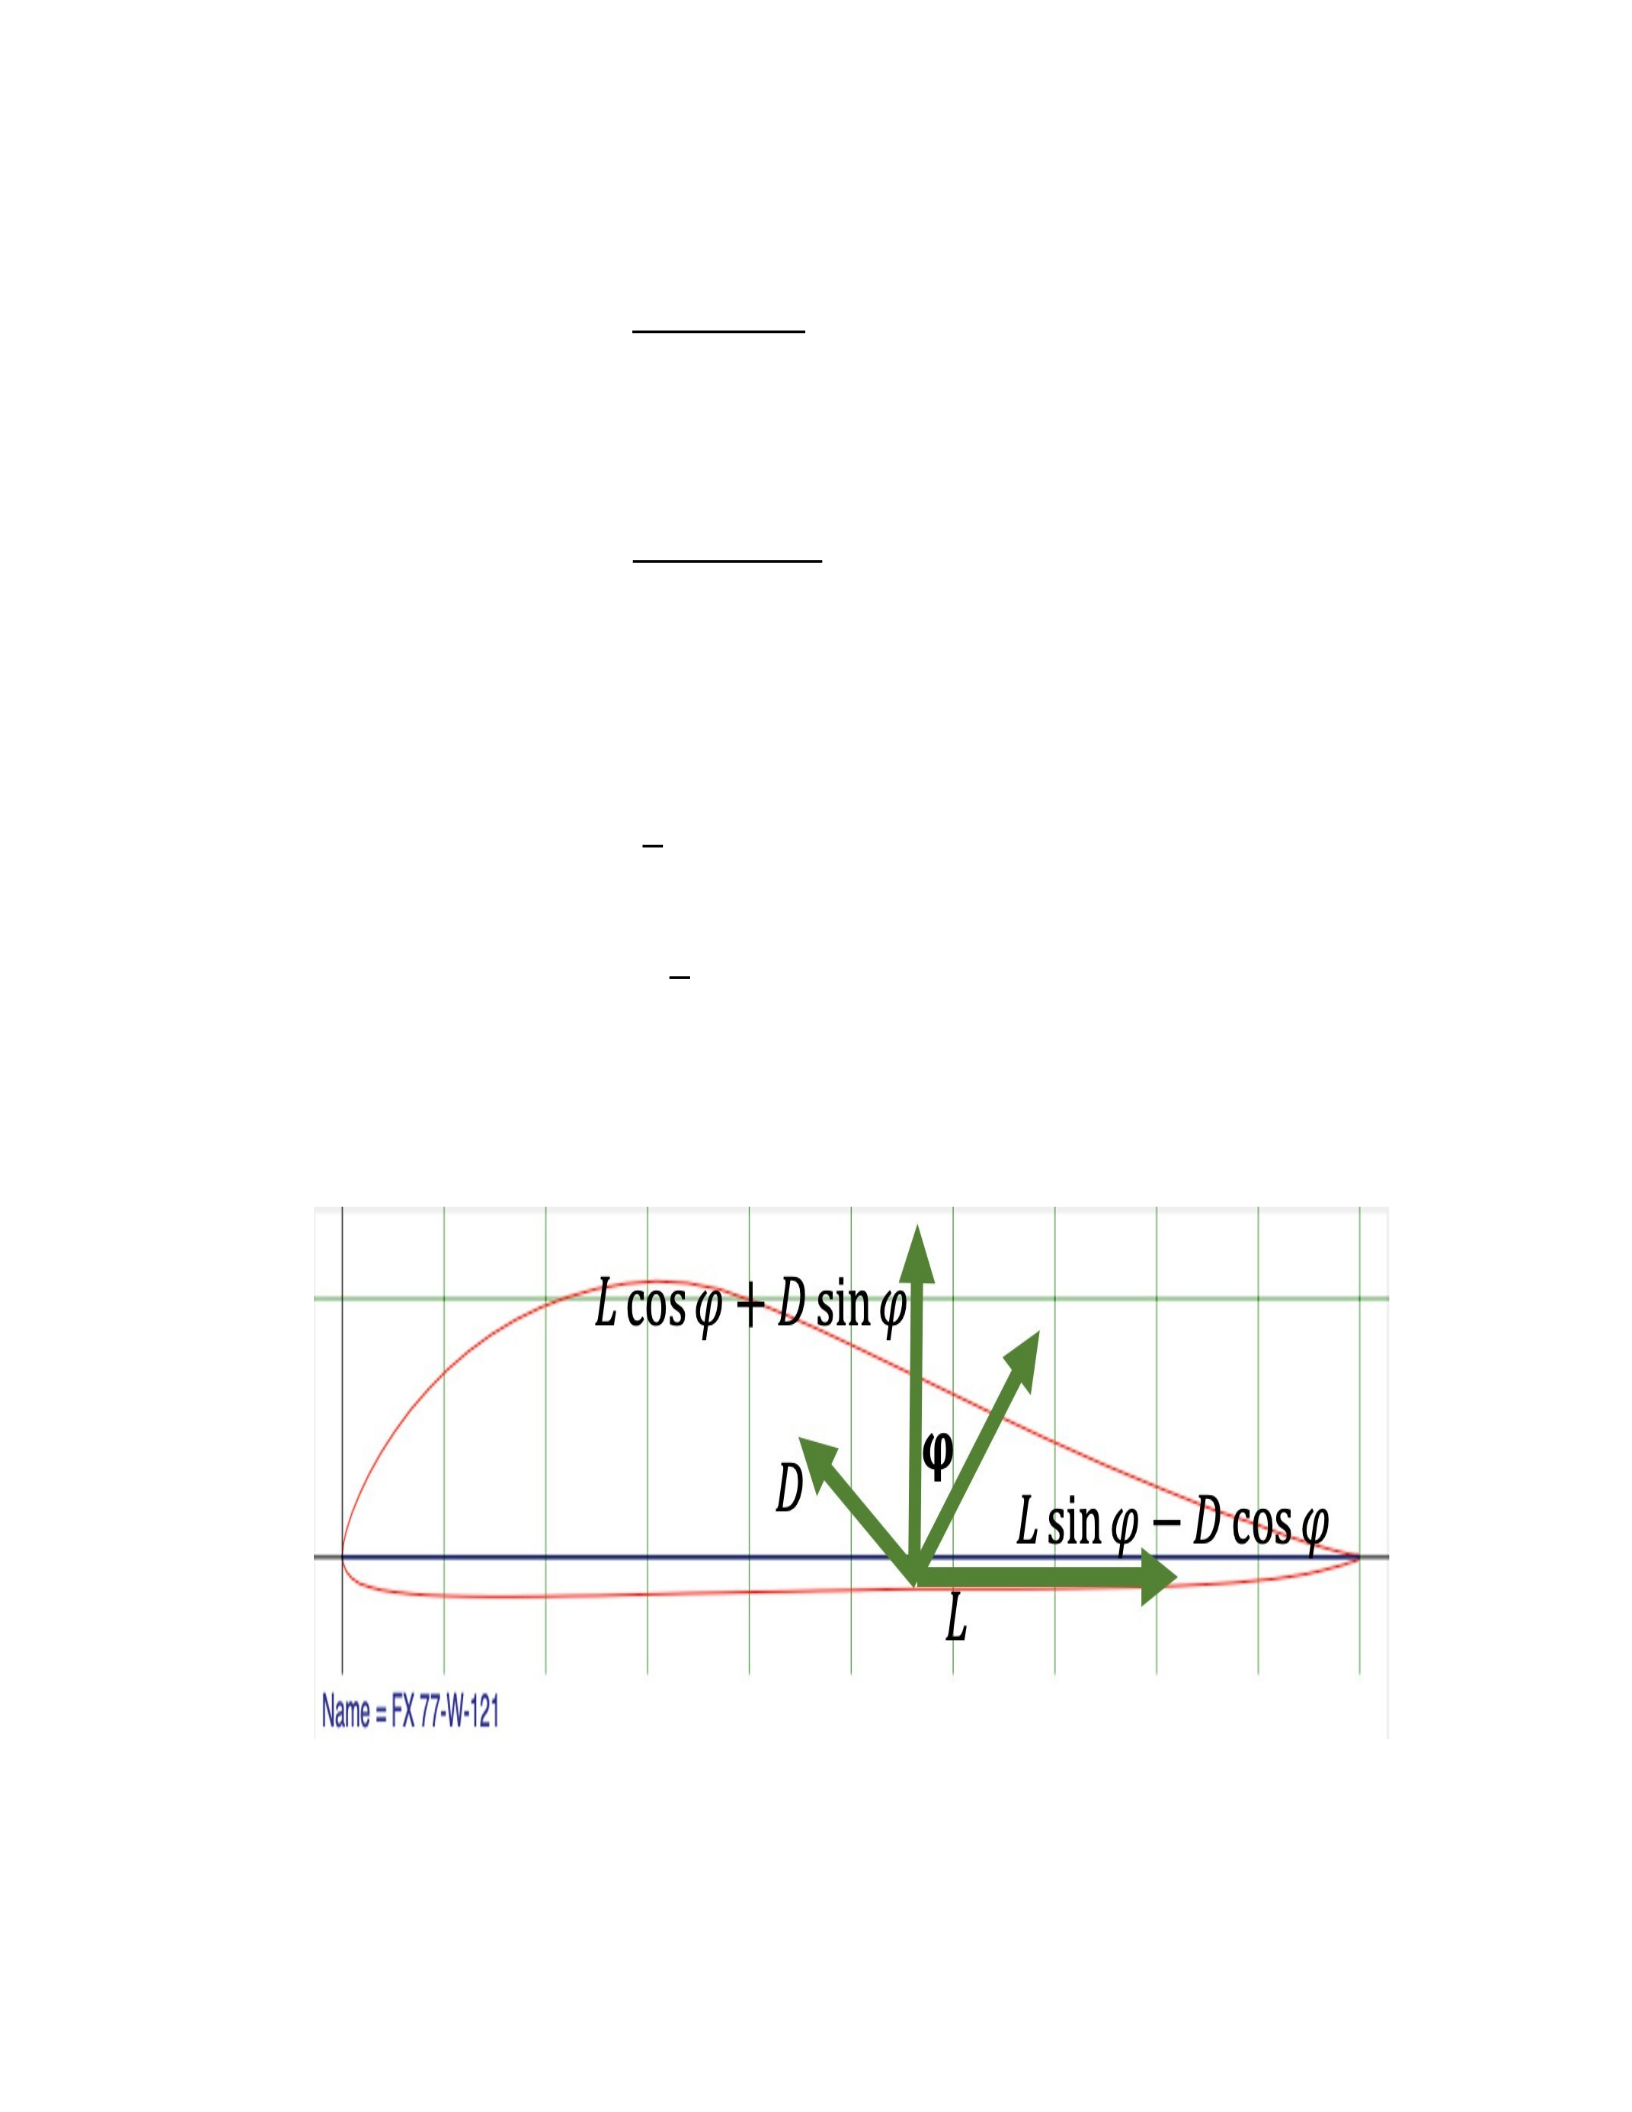
62
And
What
φ =
Ωr(1 + a′)
𝑊(4.6)
chocola
te φ =
U(1 −
a)
(4.7)
∞ Ωr(1 + a′)
where φ=α+β, as a result of the description of the aerodynamic force for each blade. Figure
4.3 shows the definition of lift and pull force of the cross-section.
1
δL = 2 ρW
1
2cClδr (4.8)
2
δD = 2 ρW Ccd (4.9)

63
FIGURE 4.3: MOMENTUM FORCE OF BLADE ELEMENTS.
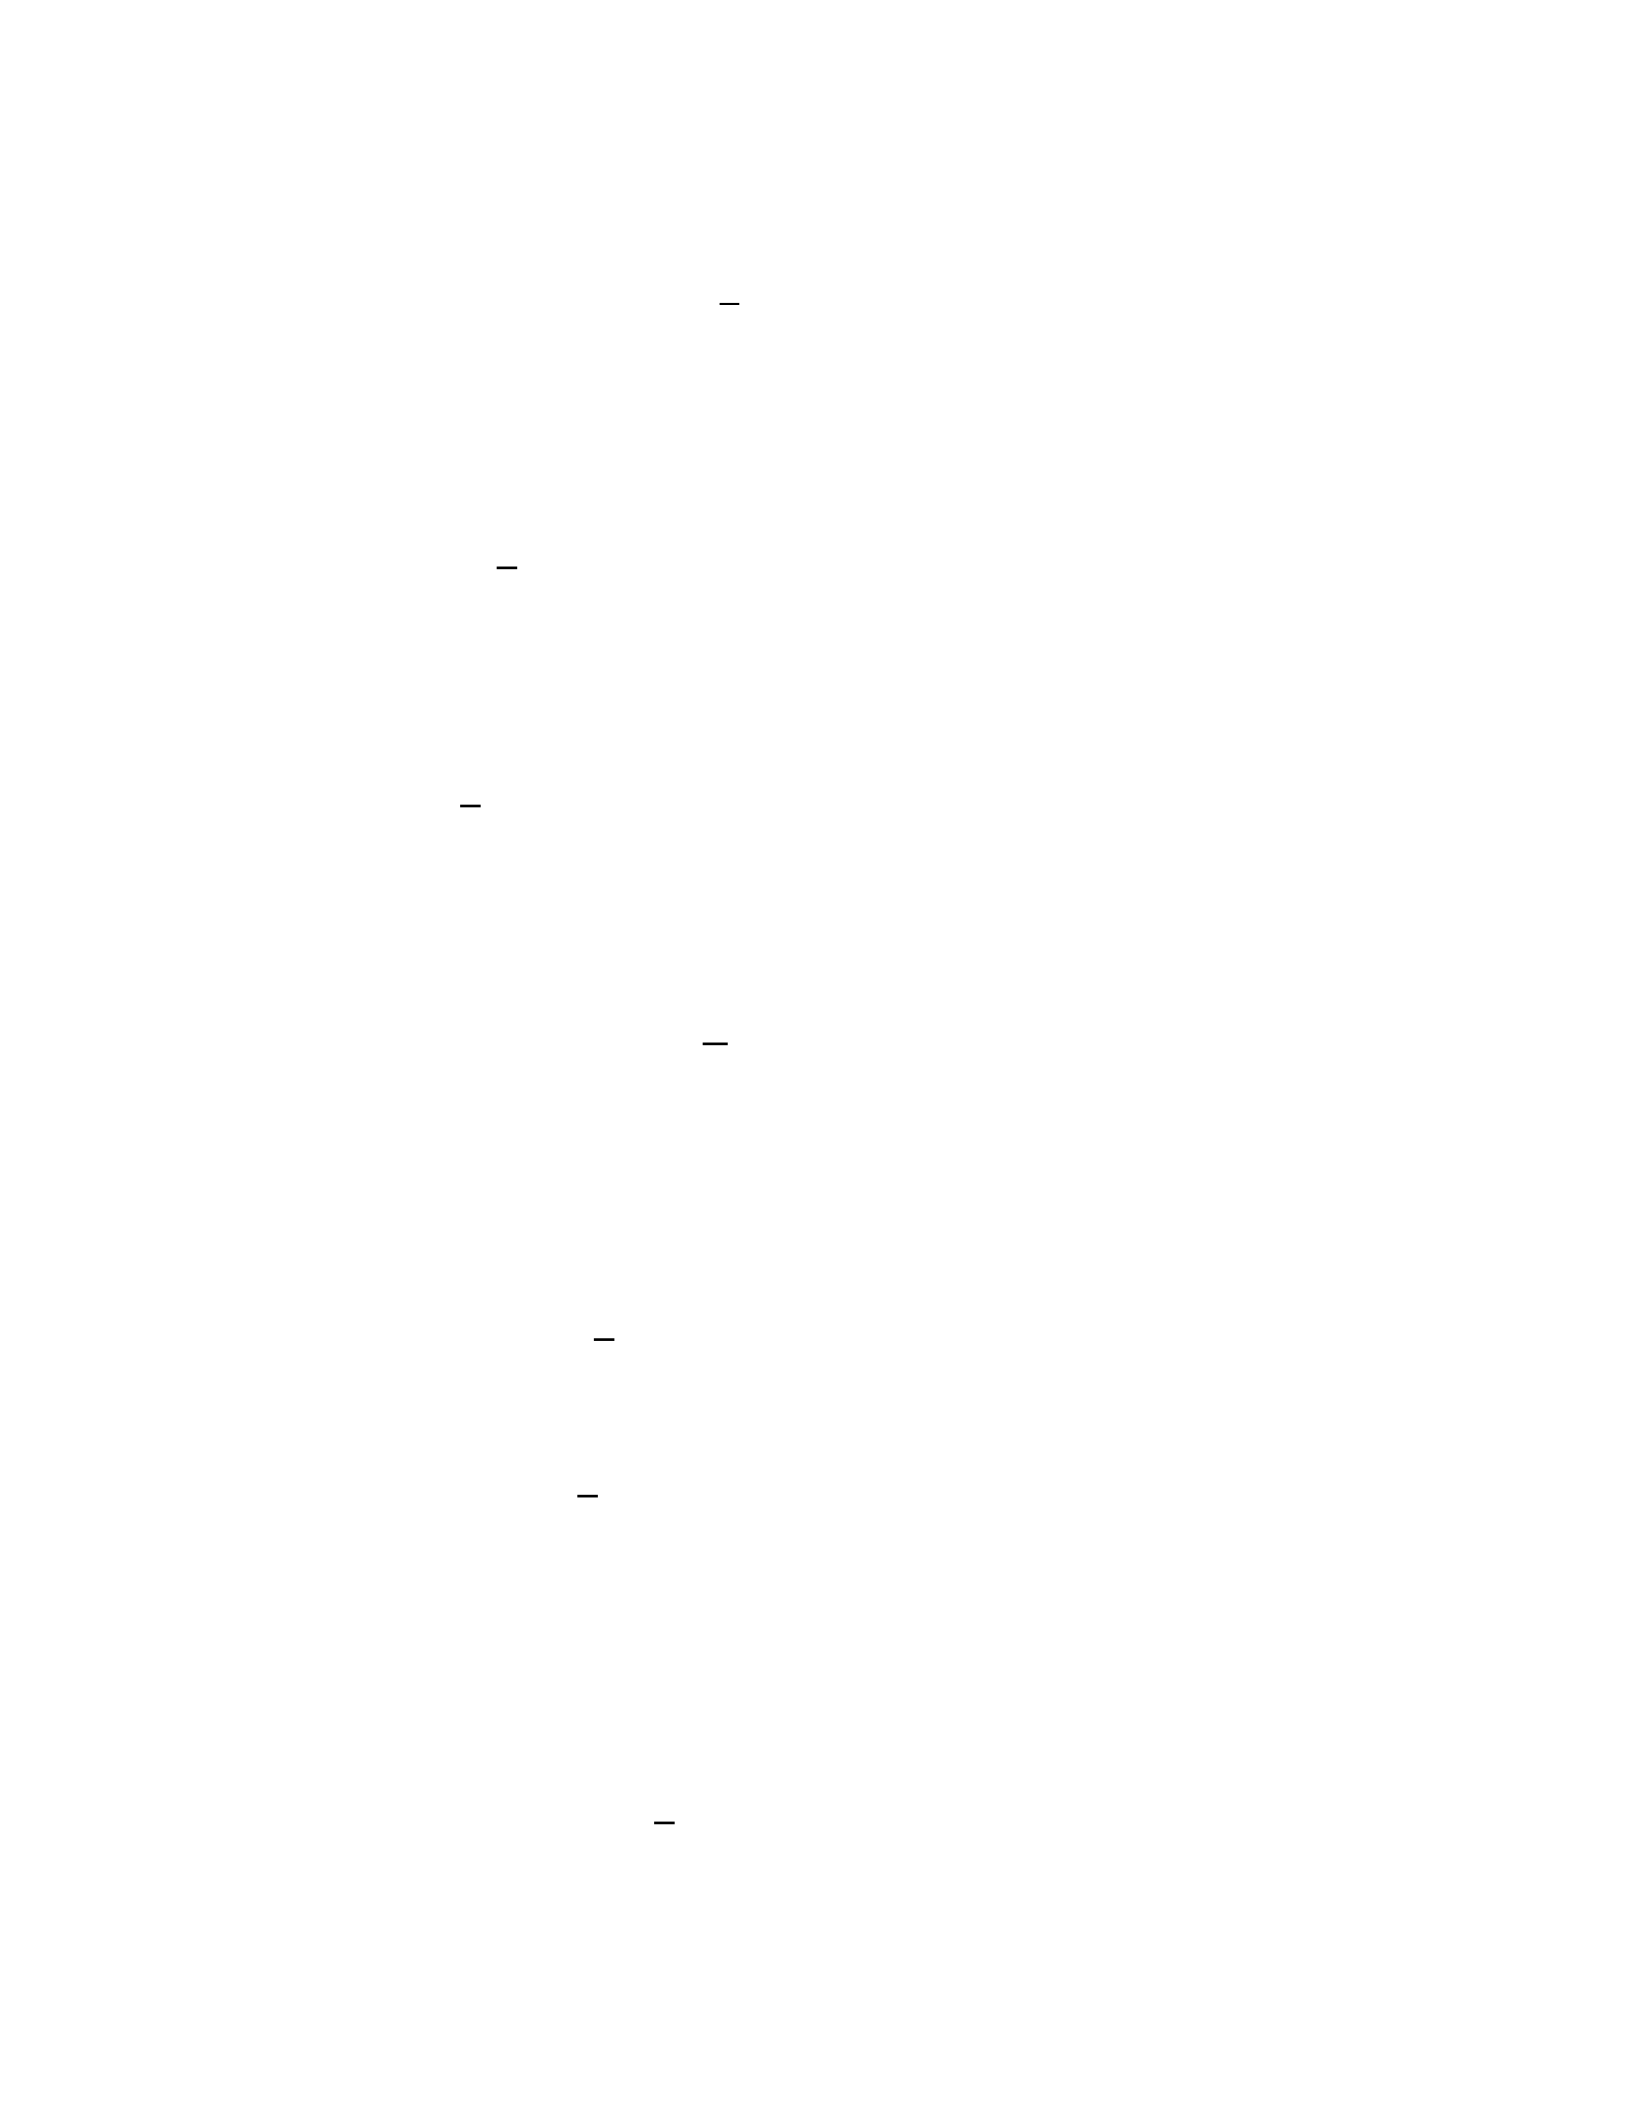
2
(
64
1
δL cos φ + δD dosa φ =
NcρW
𝐶cos φ +
Cdosa φ)δr (4.10)
2𝑙 𝑑
1
δFx = 2
NcρW2(
Cl
cos φ +
Cd
dosa φ)δr (4.11)
1
δFy =
2
NcρW2(
Cl
dosa φ
− Cd
What φ )δr (4.12)
It is very practical to
use:
μ = r
𝑅(4.13)
Cx = Cl cos φ + Cd sin φ (4.14)
Cy = Cl dosa φ − Cd cos φ (4.15)
1
δFx = 2
NcρW2
Cx
δr (4.16)
1
δFy = 2NcρW2
Cy
δr (4.17)
Differential torque,
1
δQ = r δFy
= 2
rNcρW2
Cy
δr (4.18)
And differential power,
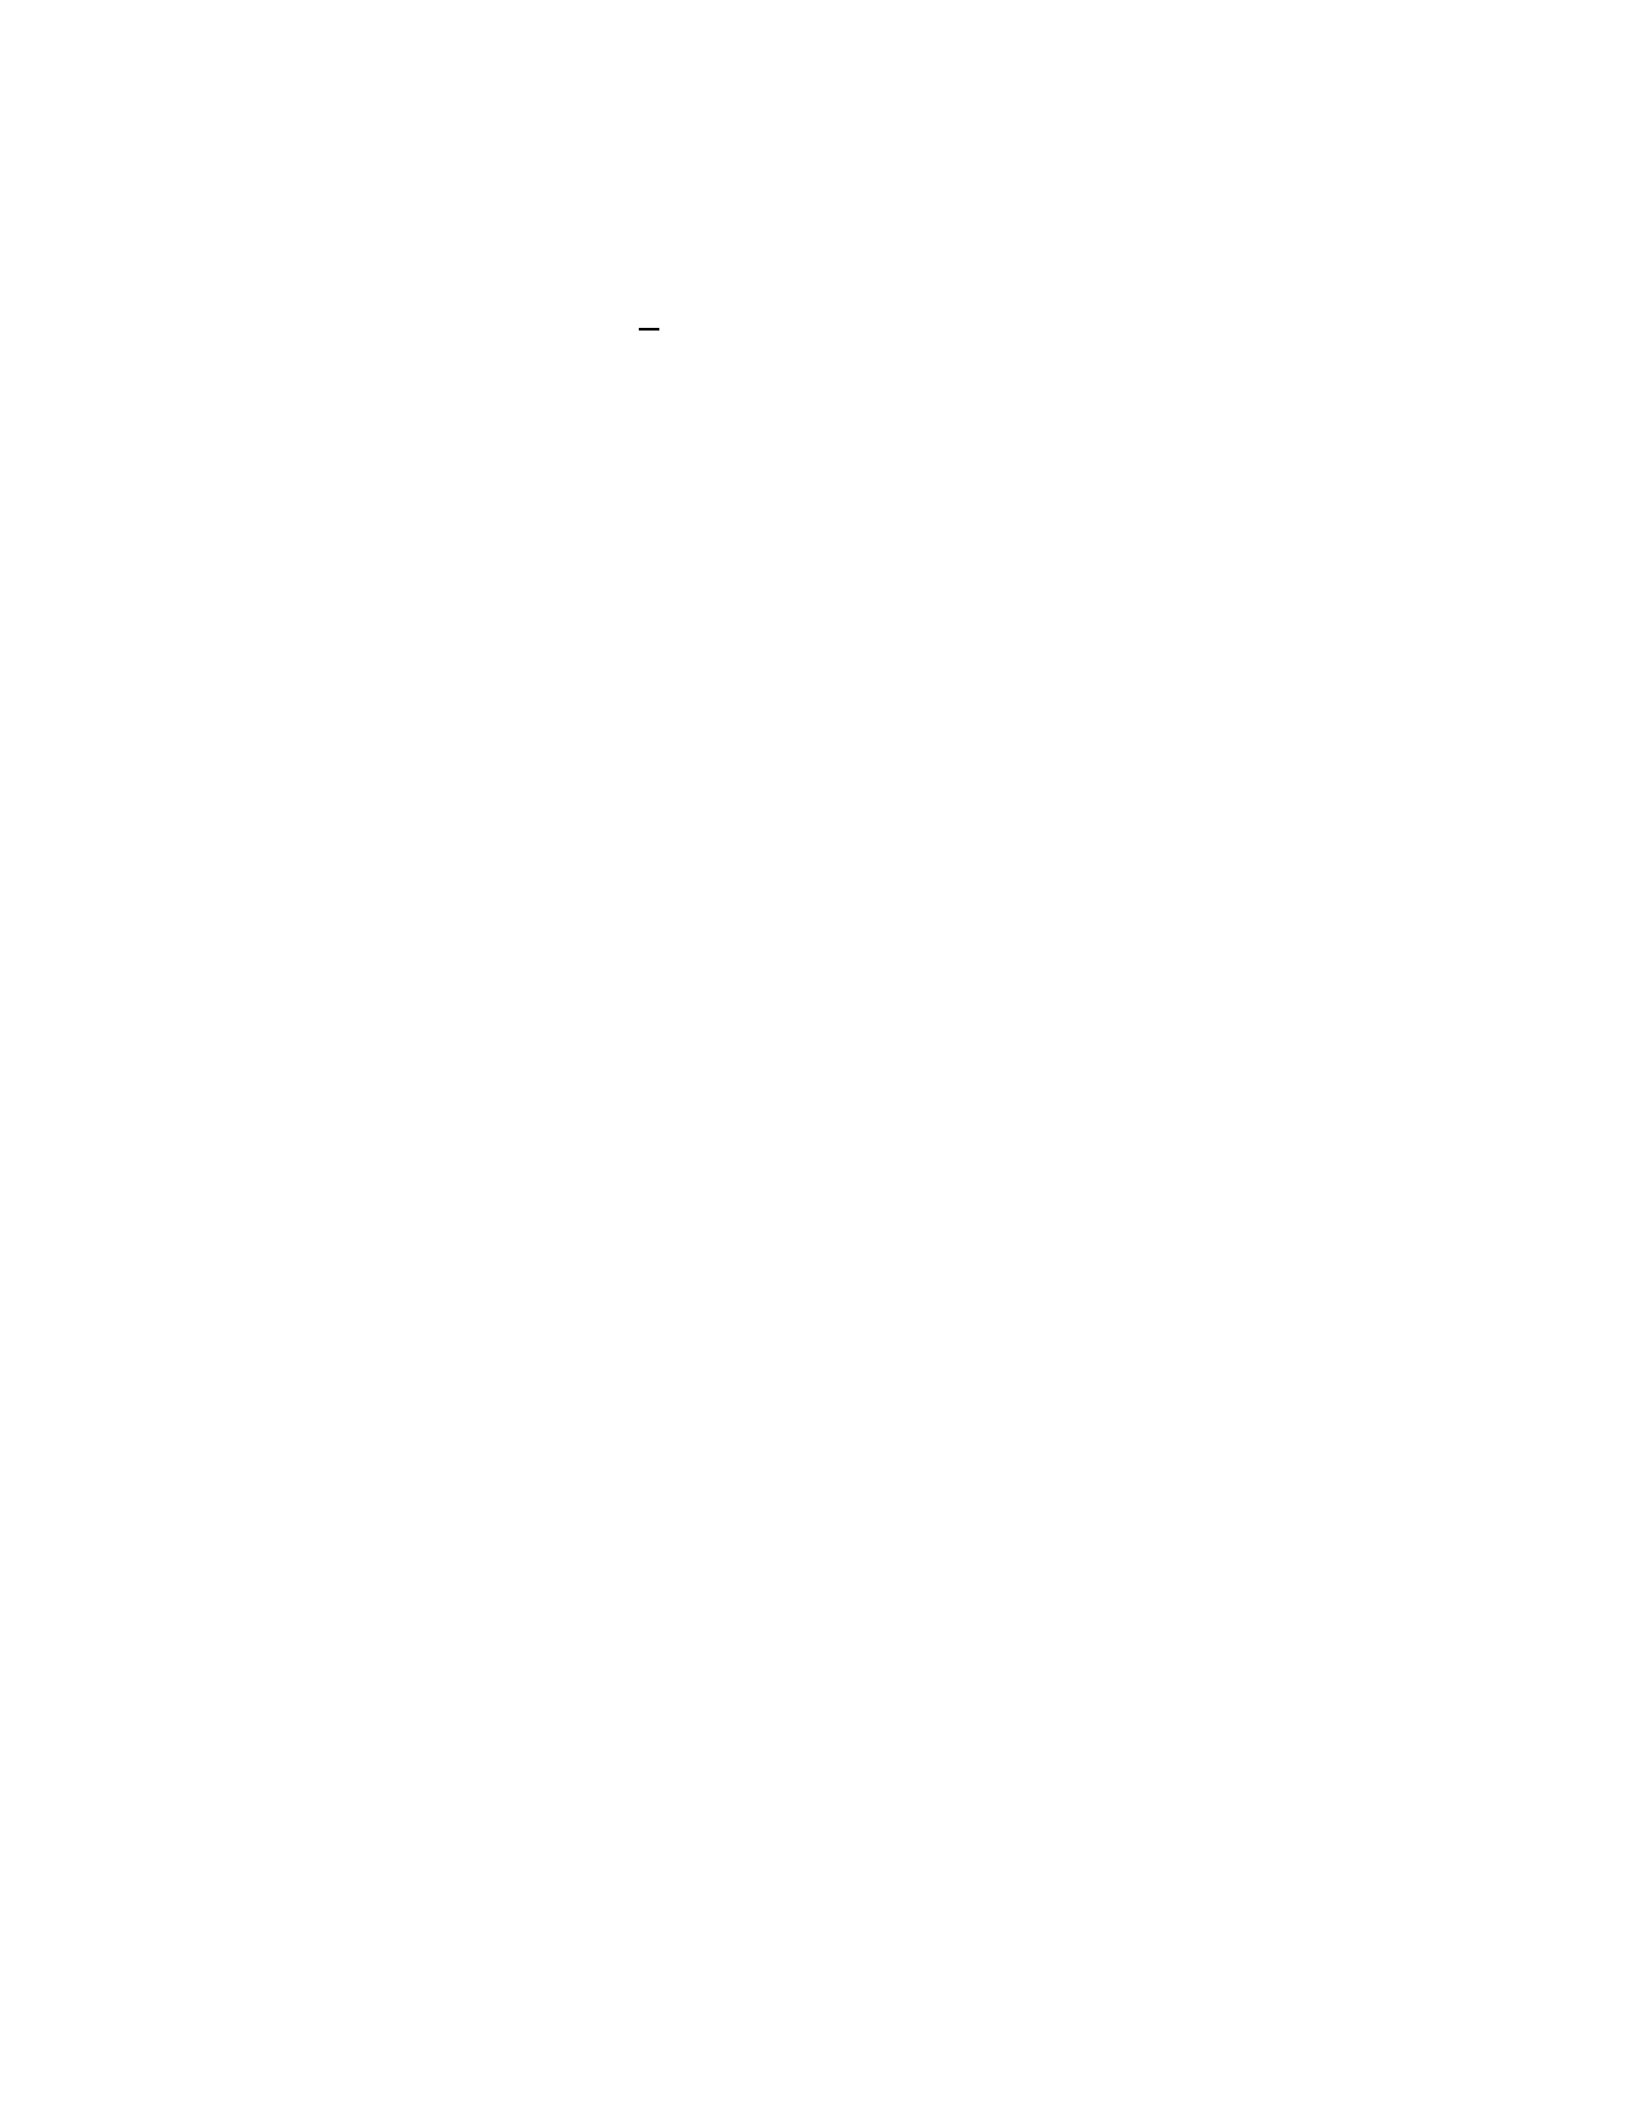
65
δP = ΩδQ =
1
2ΩrNcρW2
Cy
δr (4.19)
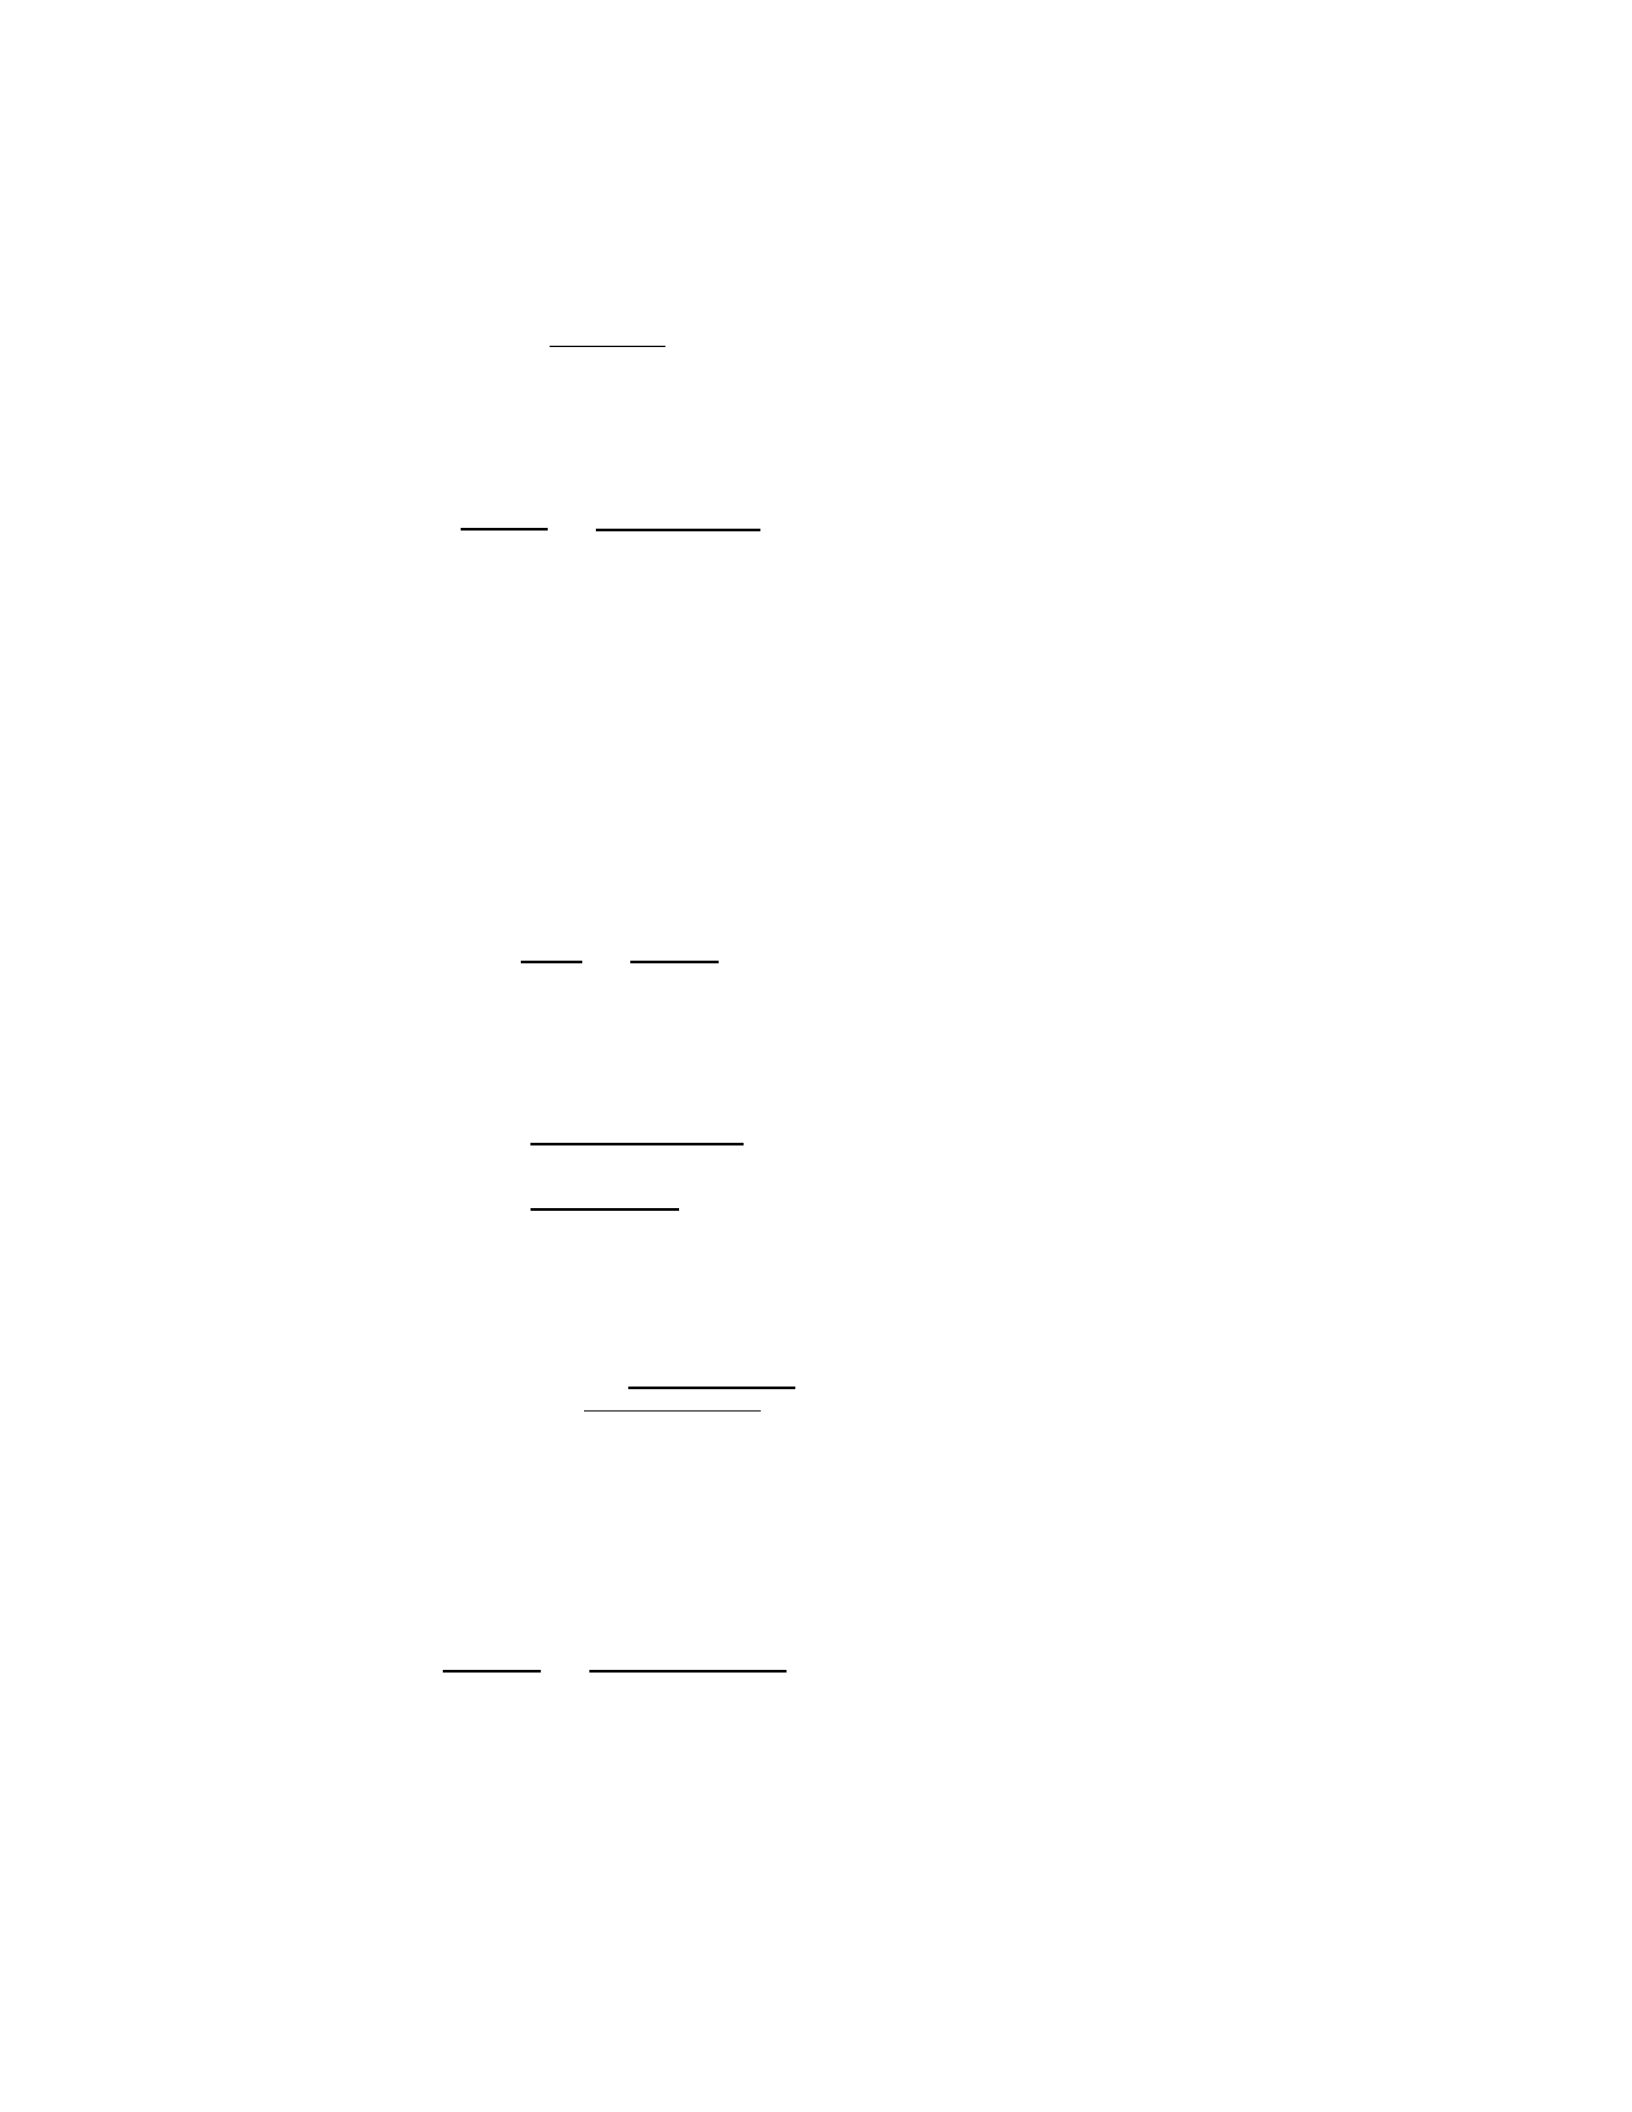
66
Let's remember,
By rearranging the
terms:
dosa φ =
U∞(1–a)
𝖶
(4.20)
a
1 −
a
=N Cxc
8πr
dosa 2φ
(4.21)
Let's define a new parameter, σr where σr is the chord solidity, which is
calculated by dividing the circular length on a given radius by the entire length of
the bar chord on that radius. [73]
Sr
= N
c2π
r
=Nc
2A
MR
(4.22)
a = 1
4(dosa
φ)2
σrCx
(4.23)
a
′
=
1
4 SiN φ Cos φ–1
σrCy
(4.24)
Since this system is not linear, the following equation is used in a iterative process to obtain
axial and tangential induction factors using the characteristics of two-dimensional hydrofoils.
a′
σr
Cy
1 + a′ = 4 sins of φ because of φ (4.25)
Keep in mind that the BEM hypothesis only applies if the rotation of the blades is uniform.
PRANDTL FORECAST FOR TIP-LOSS FACTOR
+
1

67
When it only affects the tip of the blade by lowering the lift force and creating torque,
this effect is known as tip loss. The lowered torque is the result of reduced power. We have the
following based on Ludwig Prandtl's tip loss factor:
68
2
F = π
cos
–1ee
–f
f
(4.26)
f = N(R −
r) 2rsin∅ (4.27)
In addition
r ≤ 0,6: F ≈ 1 &
r
𝑅
𝑅
> 0.6: F < 1 (4.28)
δQ = 4FprU∞a
′
(1 − a)Ωr3δr (4.29)
δP = ΩδQ = 4FπρU∞a
′
(1 − a)Ω2r3δr (4.30)
Generally
𝑟 ≤ 0,6 ∶ F ≃
1
𝑅
𝑟 > 0,6 ∶ F <
1
𝑅
(4.31)
Due to the repetitive solution, a new equation will be derived to determine the induction factor by
incorporating the tip-loss factor into the calculation.
a = 1
4 Fsin φ2
σrCx
a
′
=1
4F sin φ
because of φ −
1
σrCy
o
r
+
1

69
(4.32)
(4.33)
The projected shaft power and torque can be calculated using a rotor designed at a design rotation speed
of 500 RPM using momentum theory:
dQ = 4prU∞a′(1 − a)Ωr3δr (4.34)
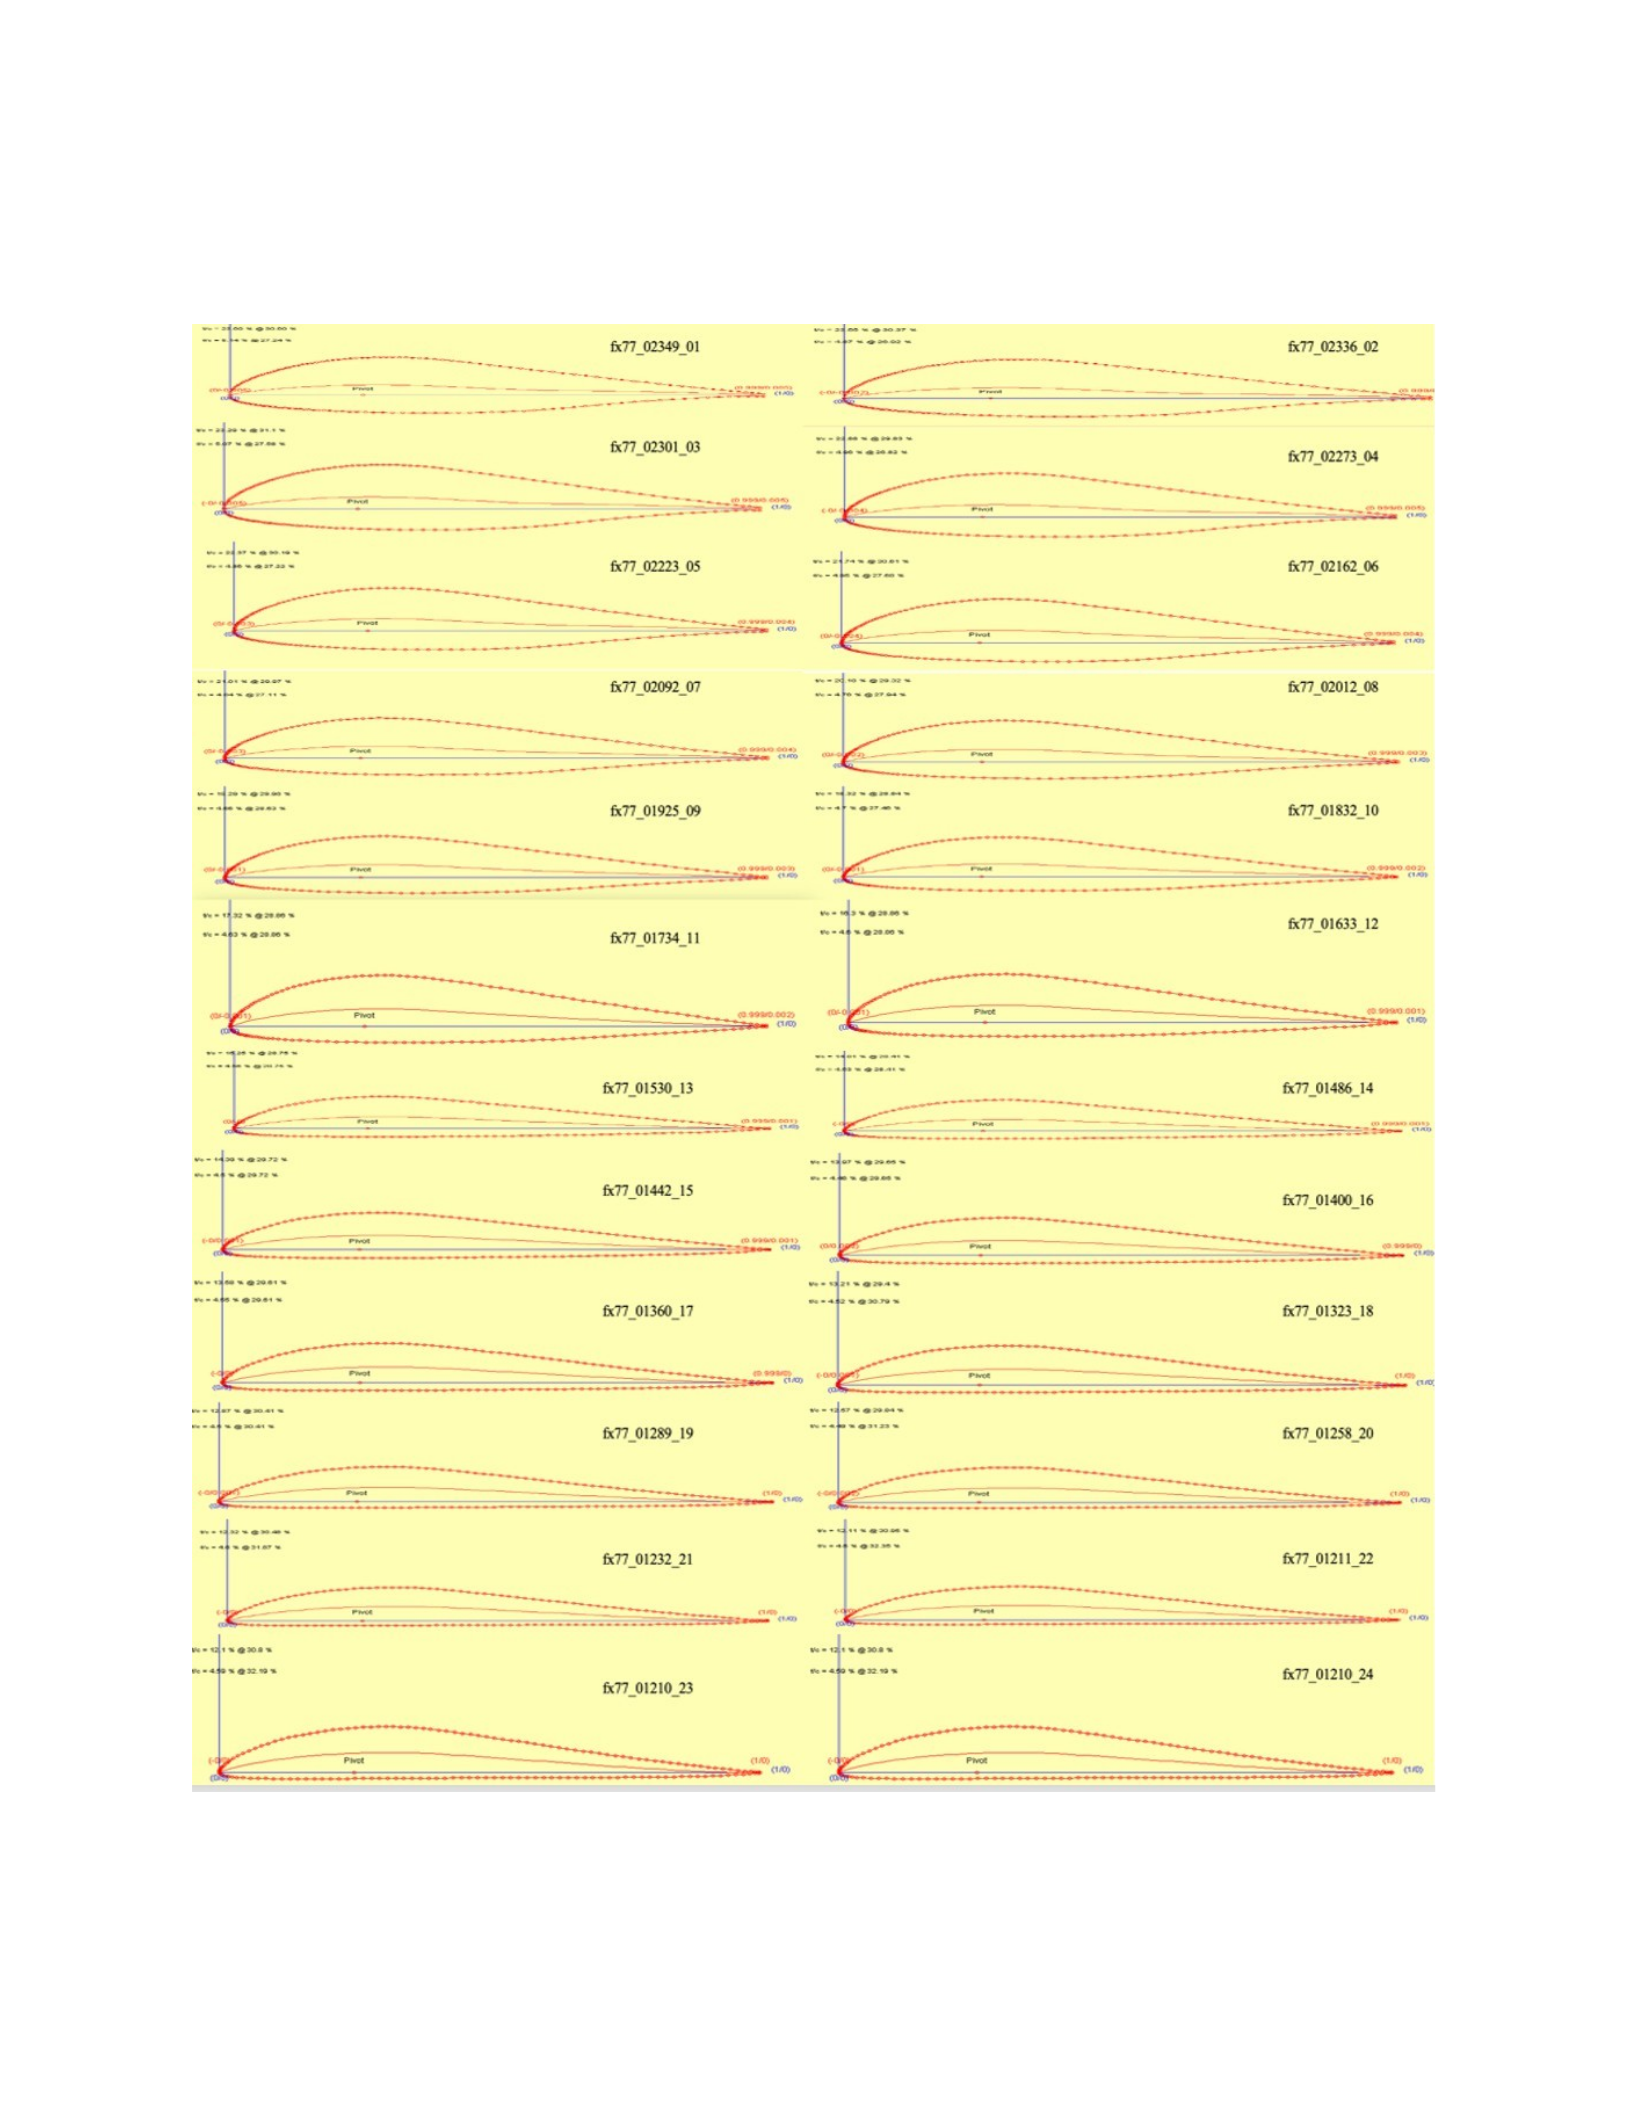
70
δP = ΩδQ = 4πρU∞a
′
(1 − a)Ω2r3δr (4.35)
Figure 4.4: Cross-sectional hydrofoil geometric shape
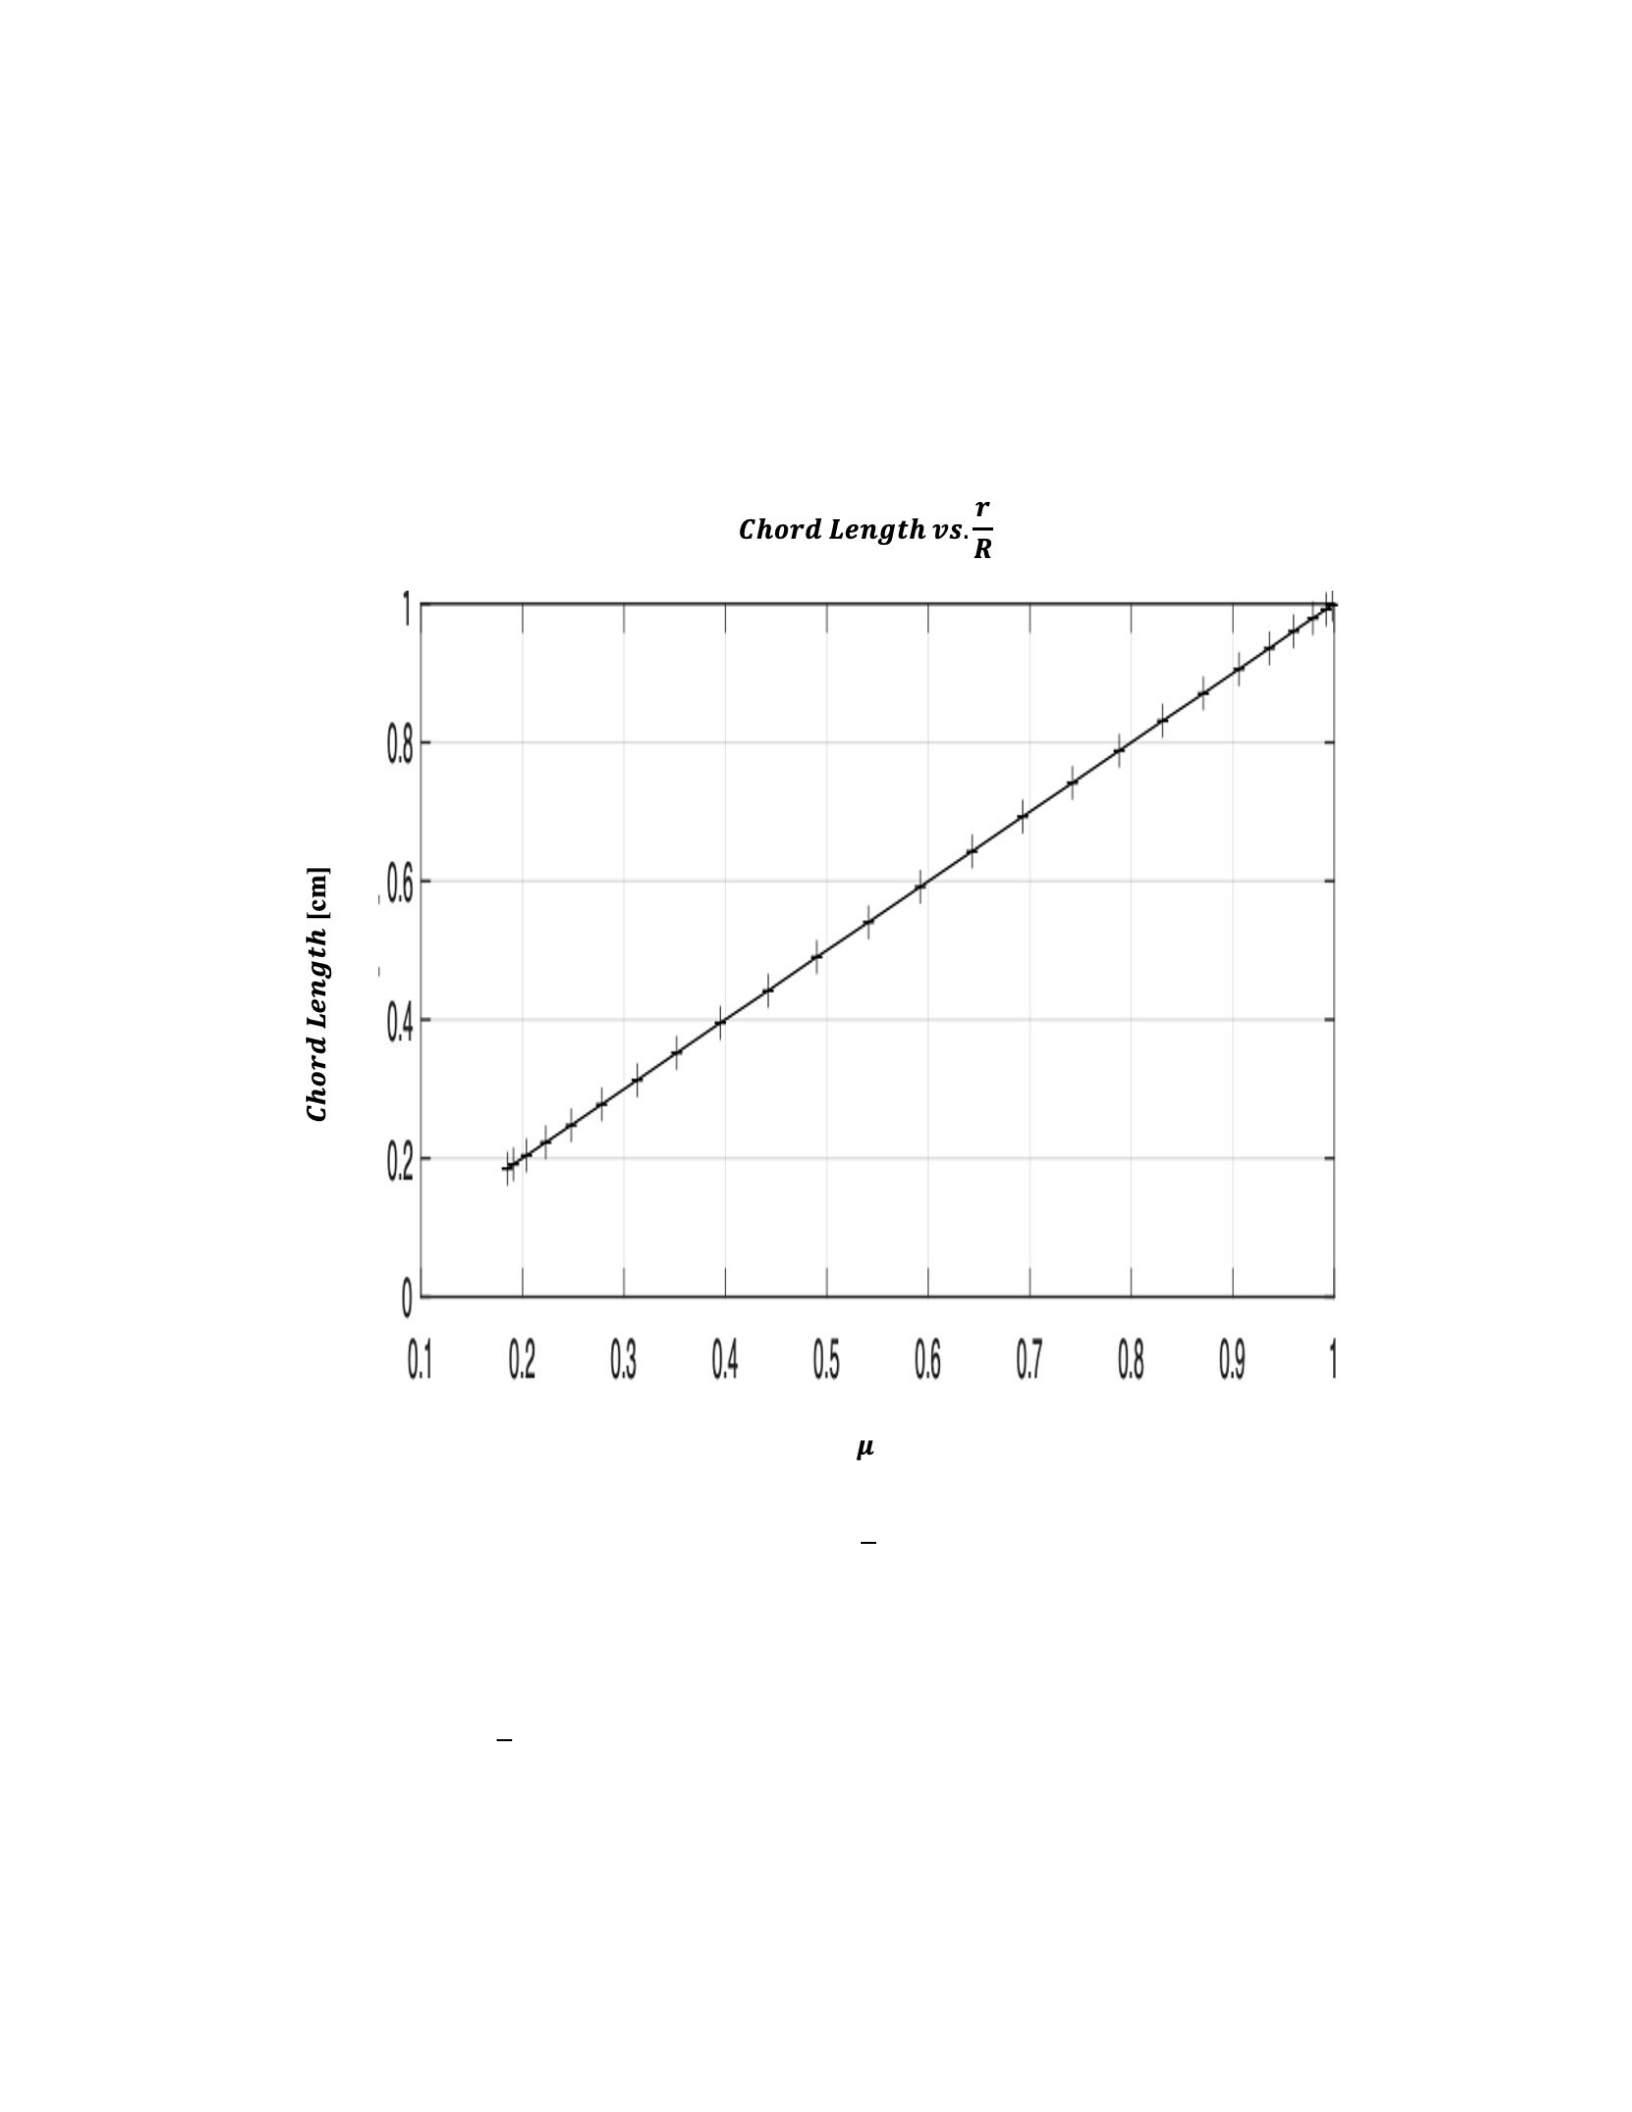
71
Figure 4.4 depicts the geometric shape of a cross-sectional hydrofoil made by JAVAFOIL with
its unique specifications as described in chapter 2.
Figure 4.5 Chord Length vs. r in full-size OCT
𝑅
The main reason for varying the length of the chord along the blade span is to optimize the
aerodynamic efficiency of the rotor. Figure 4.5 shows how long the chords of each rotor blade
are
change by increasing r. chord length of each rotor blade varies with radial position (r/r) to
𝑅
Optimize aerodynamic performance, structural integrity and rotor control. Scientific
The principle behind this variation involves considering tip speed ratios, angle of attack, lift
distribution, structural loading, and aerodynamic efficiency. The design process typically relies
on mathematical modeling and computational analysis to achieve the desired chord distribution
for a particular rotor application. Aerodynamic loading on the rotor blades increases with

72
radials
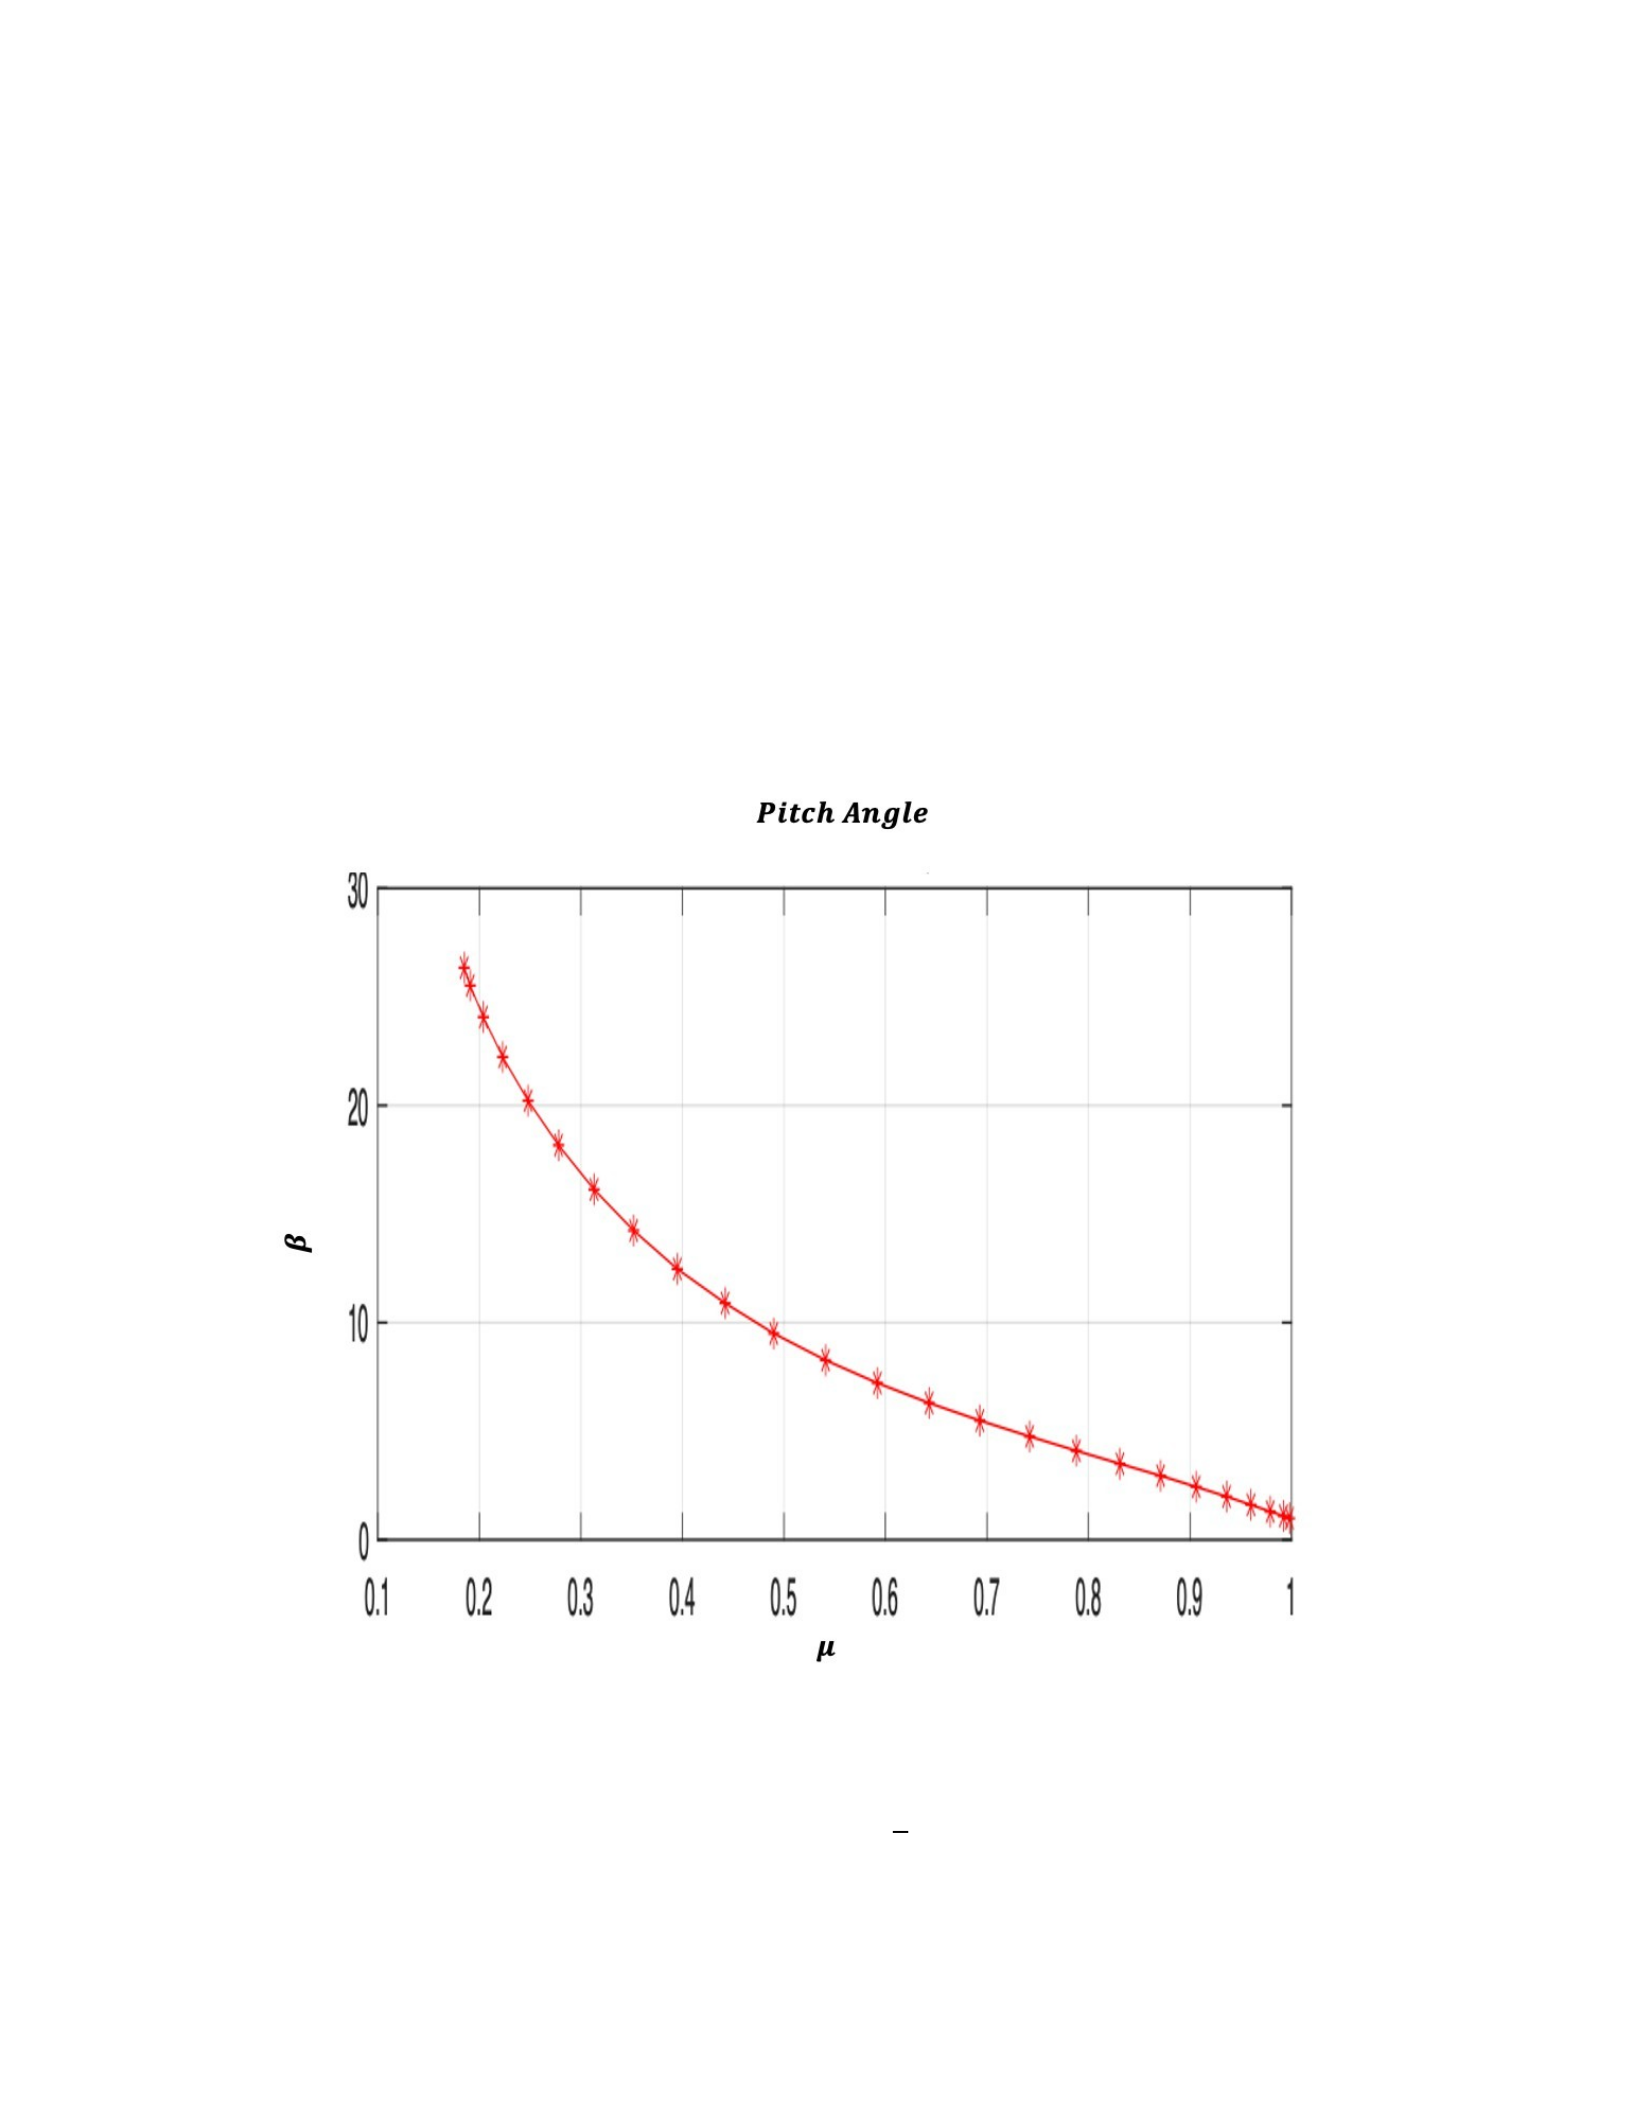
73
distance. To maintain a consistent level of aerodynamic loading, chord taper helps to adjust the
local lift coefficient as needed. This optimization minimizes the risk of stalling (sudden loss of
lift) at the blade end, where airflow conditions can be challenging. The lade experiences an
increasing centrifugal force with radial distance from the hub. Increasing the length of the chord
near the root helps distribute this load and maintain structural integrity. Conversely, reducing the
chord towards the end reduces weight and aerodynamic drag. The lift produced by each blade
section varies with the radial position due to the difference in airflow velocity and the local
Mounting Angle (AOA). To achieve a relatively uniform distribution of lift along the blade span,
chord length adjustment is required. For example, at the root of the blade where the rotation
speed is lower, a longer chord may be required to produce sufficient lift. To maintain efficient
elevator generation and minimize drag, it is important to control the AoA. The blades are
designed with a specific swivel angle to ensure that the AoA is suitable for local airflow
conditions at each radial position.
Figure 4.6 Pitch angle length vs. r in full-size OCT
𝑅

74
Figure 4.6 is a graph "Pitch Angle vs. r/R" representing the variation in the pitch angle of the
rotor blade as a function of the radial position (r) relative to the rotor radius (R). This graphic is a
fundamental aspect of the rotor blade design. The pitch angle is the angle between the chord line
(the straight line that connects the front and back edges of the blade section) and the rotor
rotation plane. This is the angle at which the blade is tilted or twisted along its length. The pitch
angle determines the angle of attack (AoA) of the blade section, which is crucial for controlling
lift and drag. In rotor systems, pitch angles typically vary along each blade to optimize
aerodynamic performance and control characteristics. The radial position (r) represents the
distance from the rotor hub, and ranges from 0 (hub) to R (blade tip). The main purpose of
varying the pitch angle along the blade span is to control the angle of attack at different radial
positions. The angle of attack is the angle between the direction of the local airflow and the
chord line of the blade section. This greatly affects the lifting force and resistance generated by
the blades. The variation in pitch angle aims to ensure that each section of the blade operates at
the optimal angle of attack for its local airflow conditions. This optimization is essential to
maximize lift (to generate thrust or lift) and minimize drag (to reduce energy loss and noise).
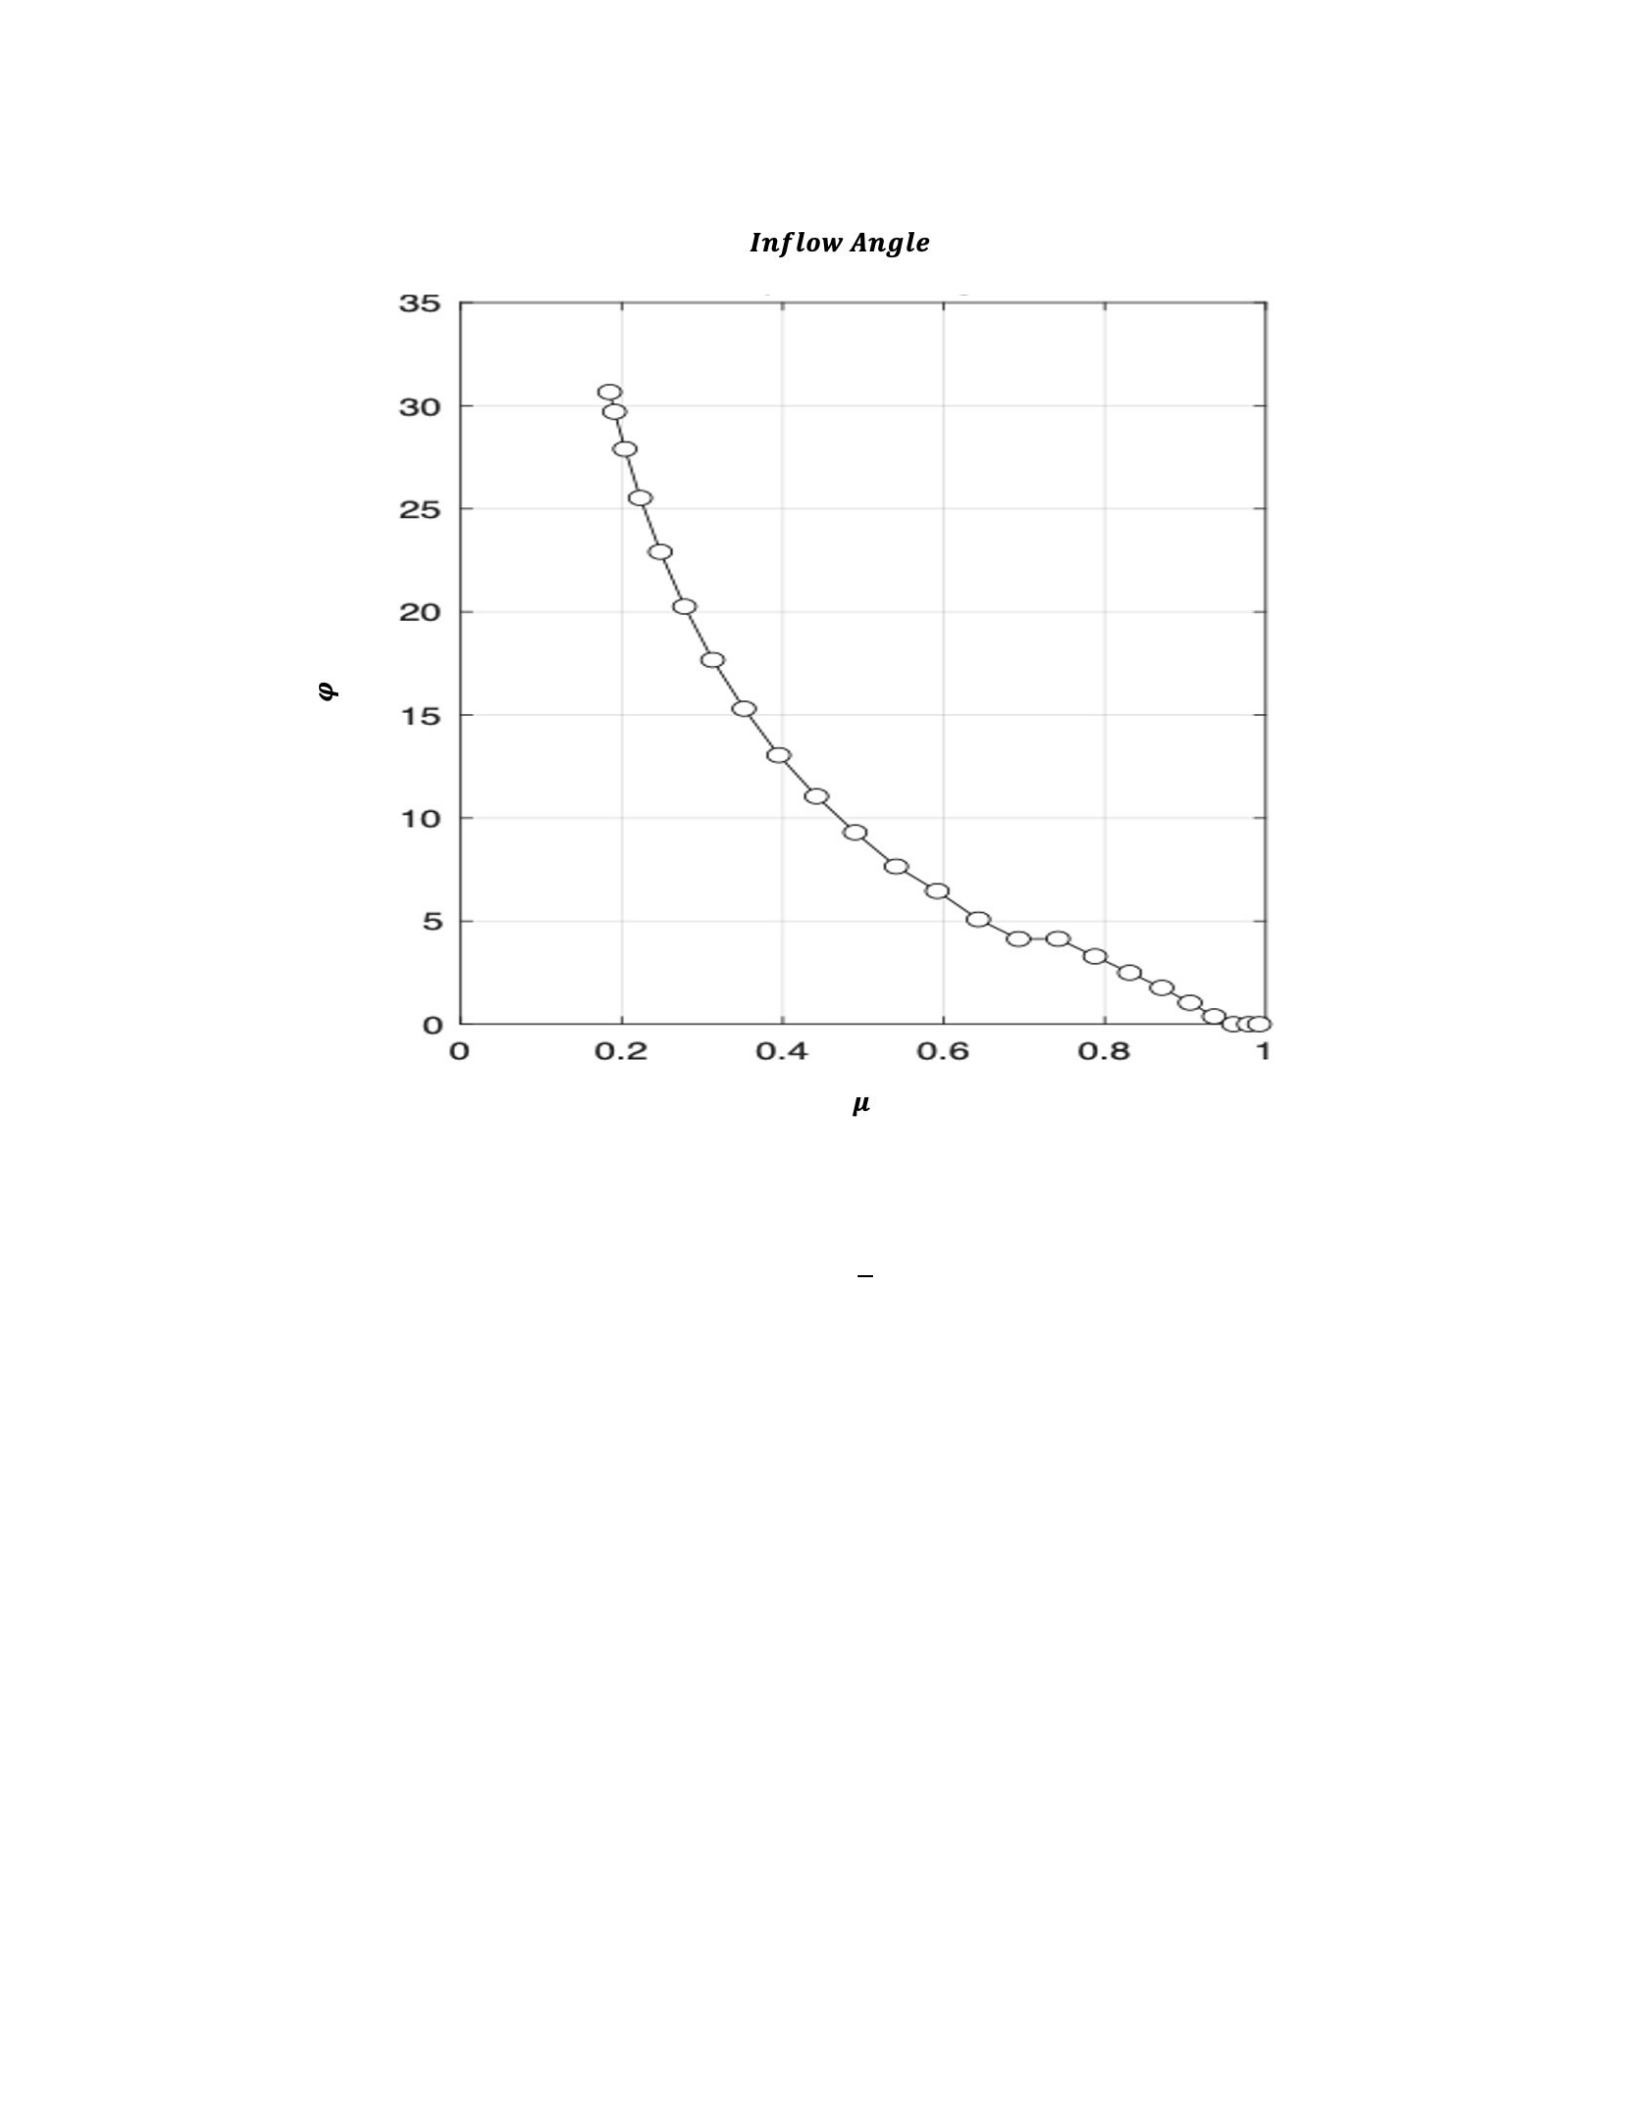
75
Figure 4.7 Inflow Angle vs. r in full-size OCT
𝑅
Figure 4.7 shows the graph "Inflow Angle vs. r/R" representing the variation in the inflow angle
of the rotor blade as a function of its radial position (r) relative to the rotor radius (R). The
inflow angle, also known as the relative water angle or relative inflow angle, is the angle
between the incoming hydroflow and the chord line of the rotor blade at a specific radial
position. It describes the direction and magnitude of the airflow that the blade encounters as it
rotates. The inflow angle varies along each rotor blade due to the complex aerodynamic
interaction between the rotor and the surrounding hydro flow.
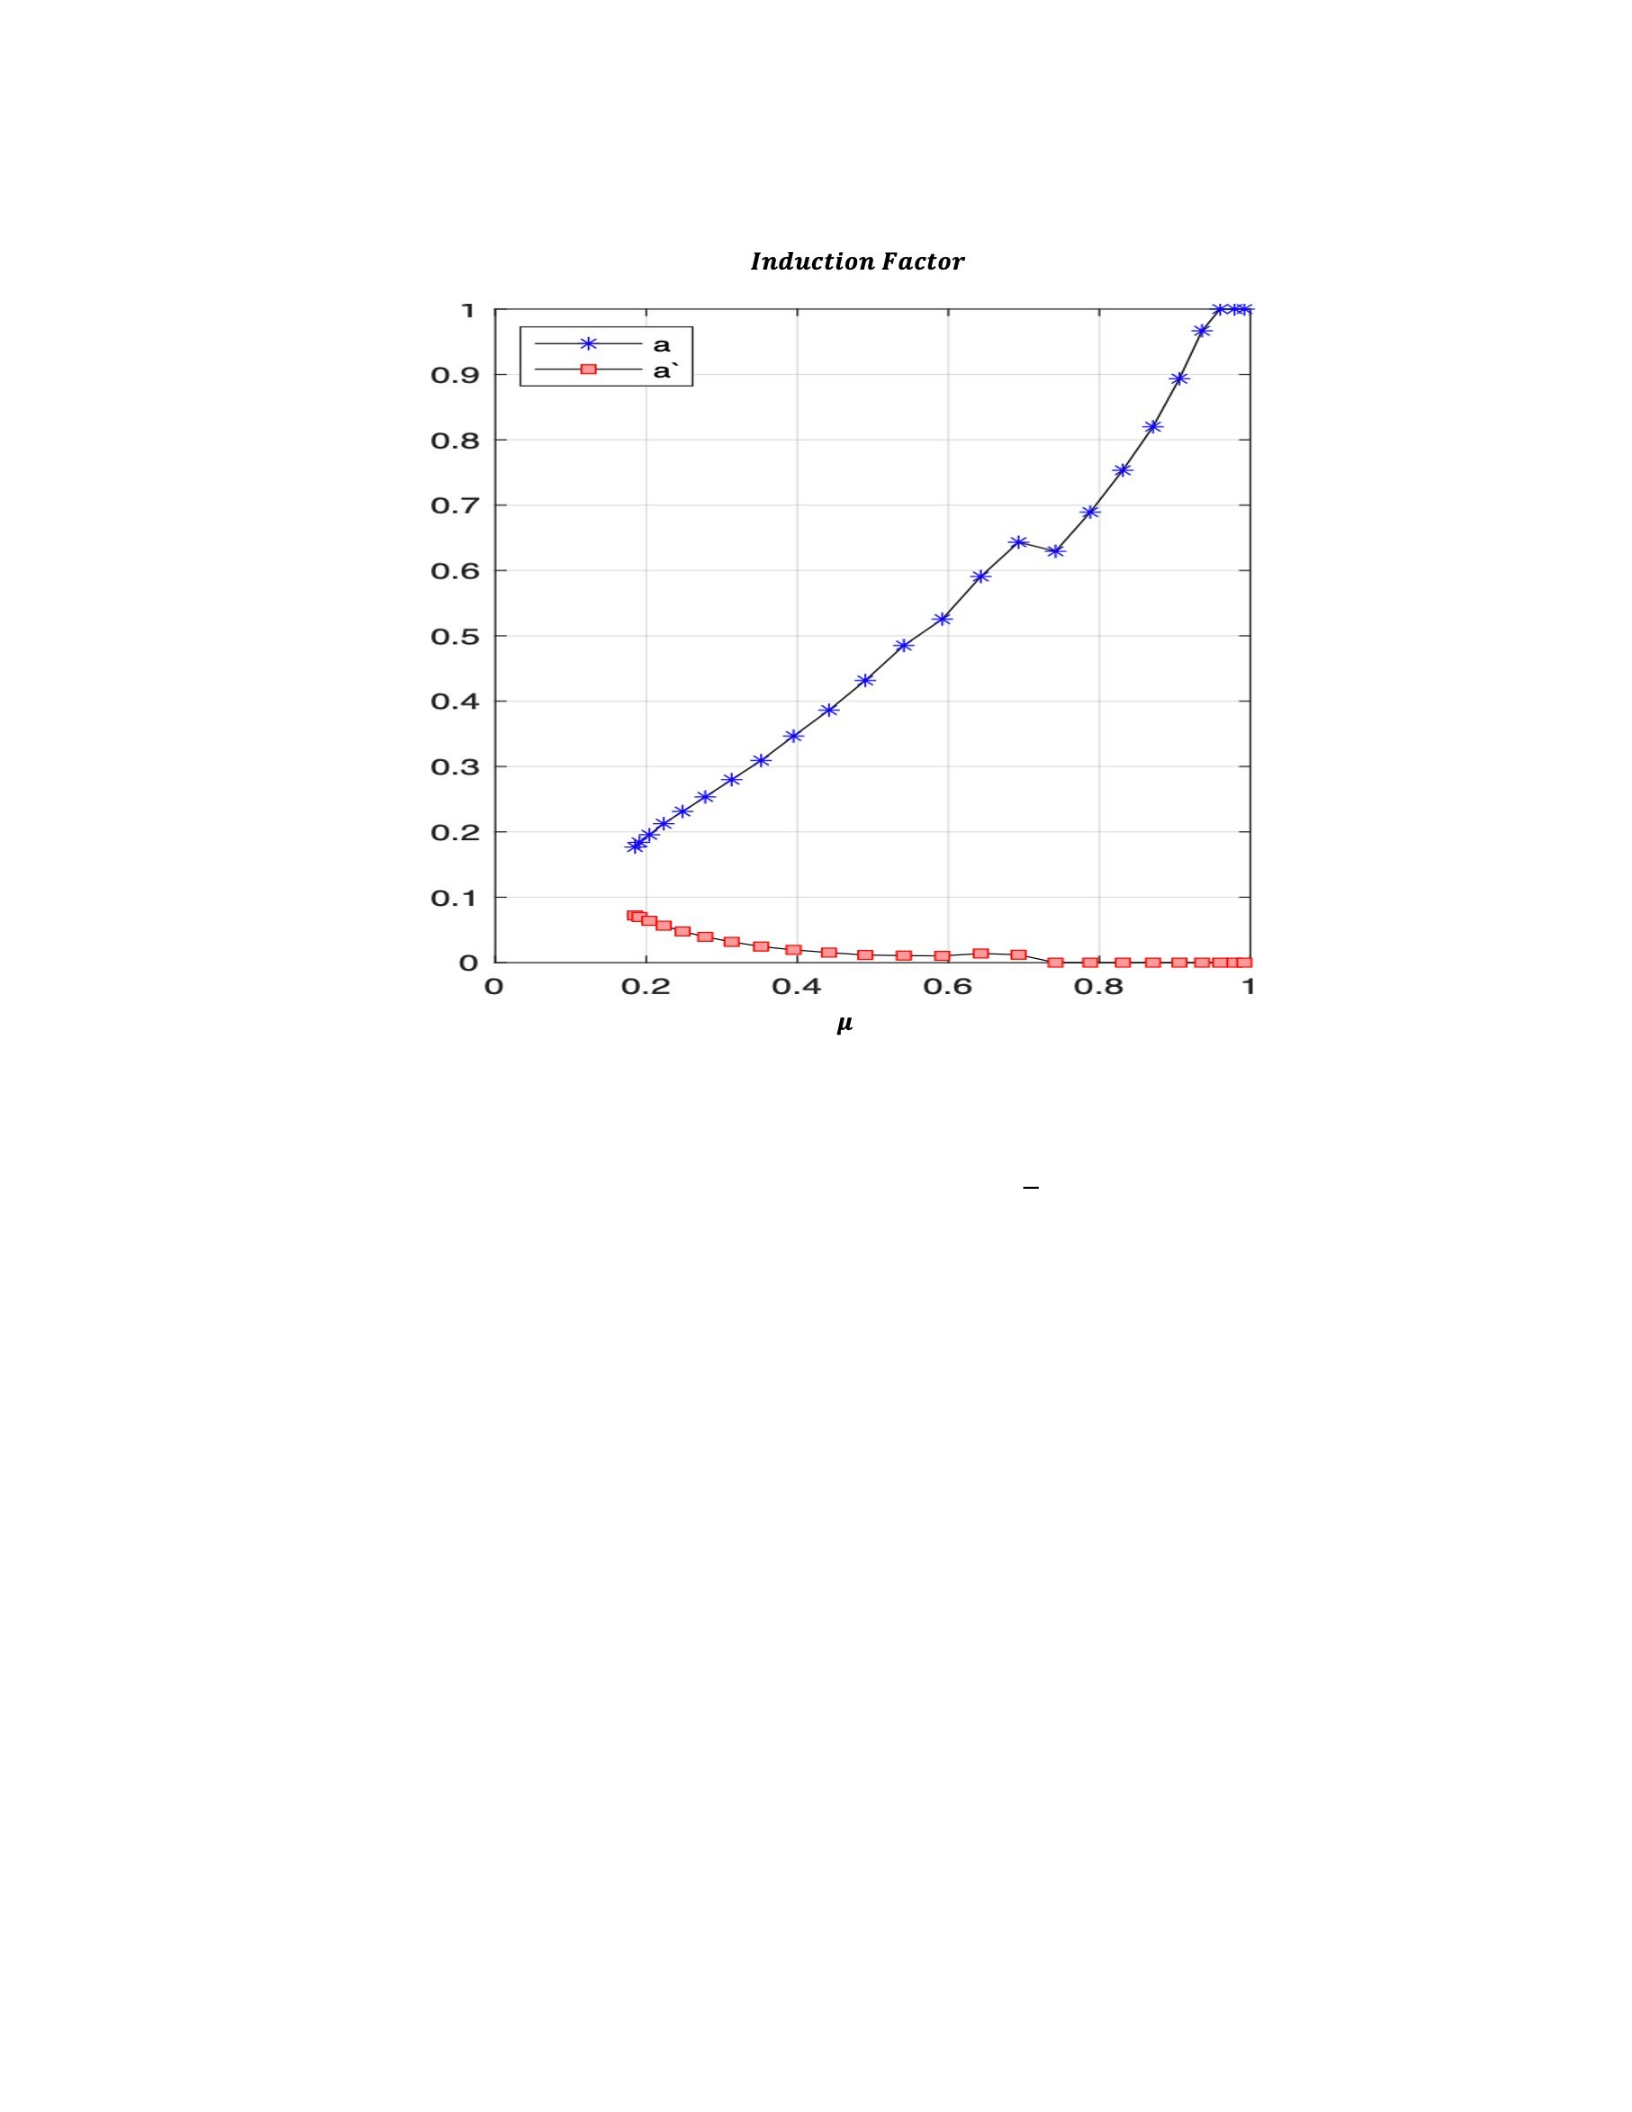
76
Figure 4.8 Axial and Tangential Induction Factors vs. r in full-size OCT
𝑅
Figure 4.8 shows the "Axial and Tangential Induction Factors vs. r/R" in a turbine representing
variations in these two main aerodynamic parameters as a function of the radial position (r)
relative to the rotor radius (R). These two parameters are critical in the analysis and design of
underwater current turbines, axial flow fans, and other rotating engines.
The axial induction factor, denoted as "a", measures the reduction in axial (horizontal) current
velocity caused by the presence of a turbine or rotor. It represents the fraction of the velocity of
the water that passes through the rotor disc and contributes to the axial thrust or axial flow. The
tangential induction factor, denoted as "a'," measures the reduction in tangential water velocity
(rotation) induced by the rotor. It represents the fraction of the tangential current velocity
converted into rotational kinetic energy by the rotor blades. Engineers analyze and design
turbines to optimize the distribution of axial and tangential induction factors along the range of
rotor blades. The goal is to maximize the extraction of kinetic energy from the wind while
maintaining efficient and controlled operations. This analysis helps predict how changes in these
factors affect turbine efficiency, power output, and load on the rotor blades.
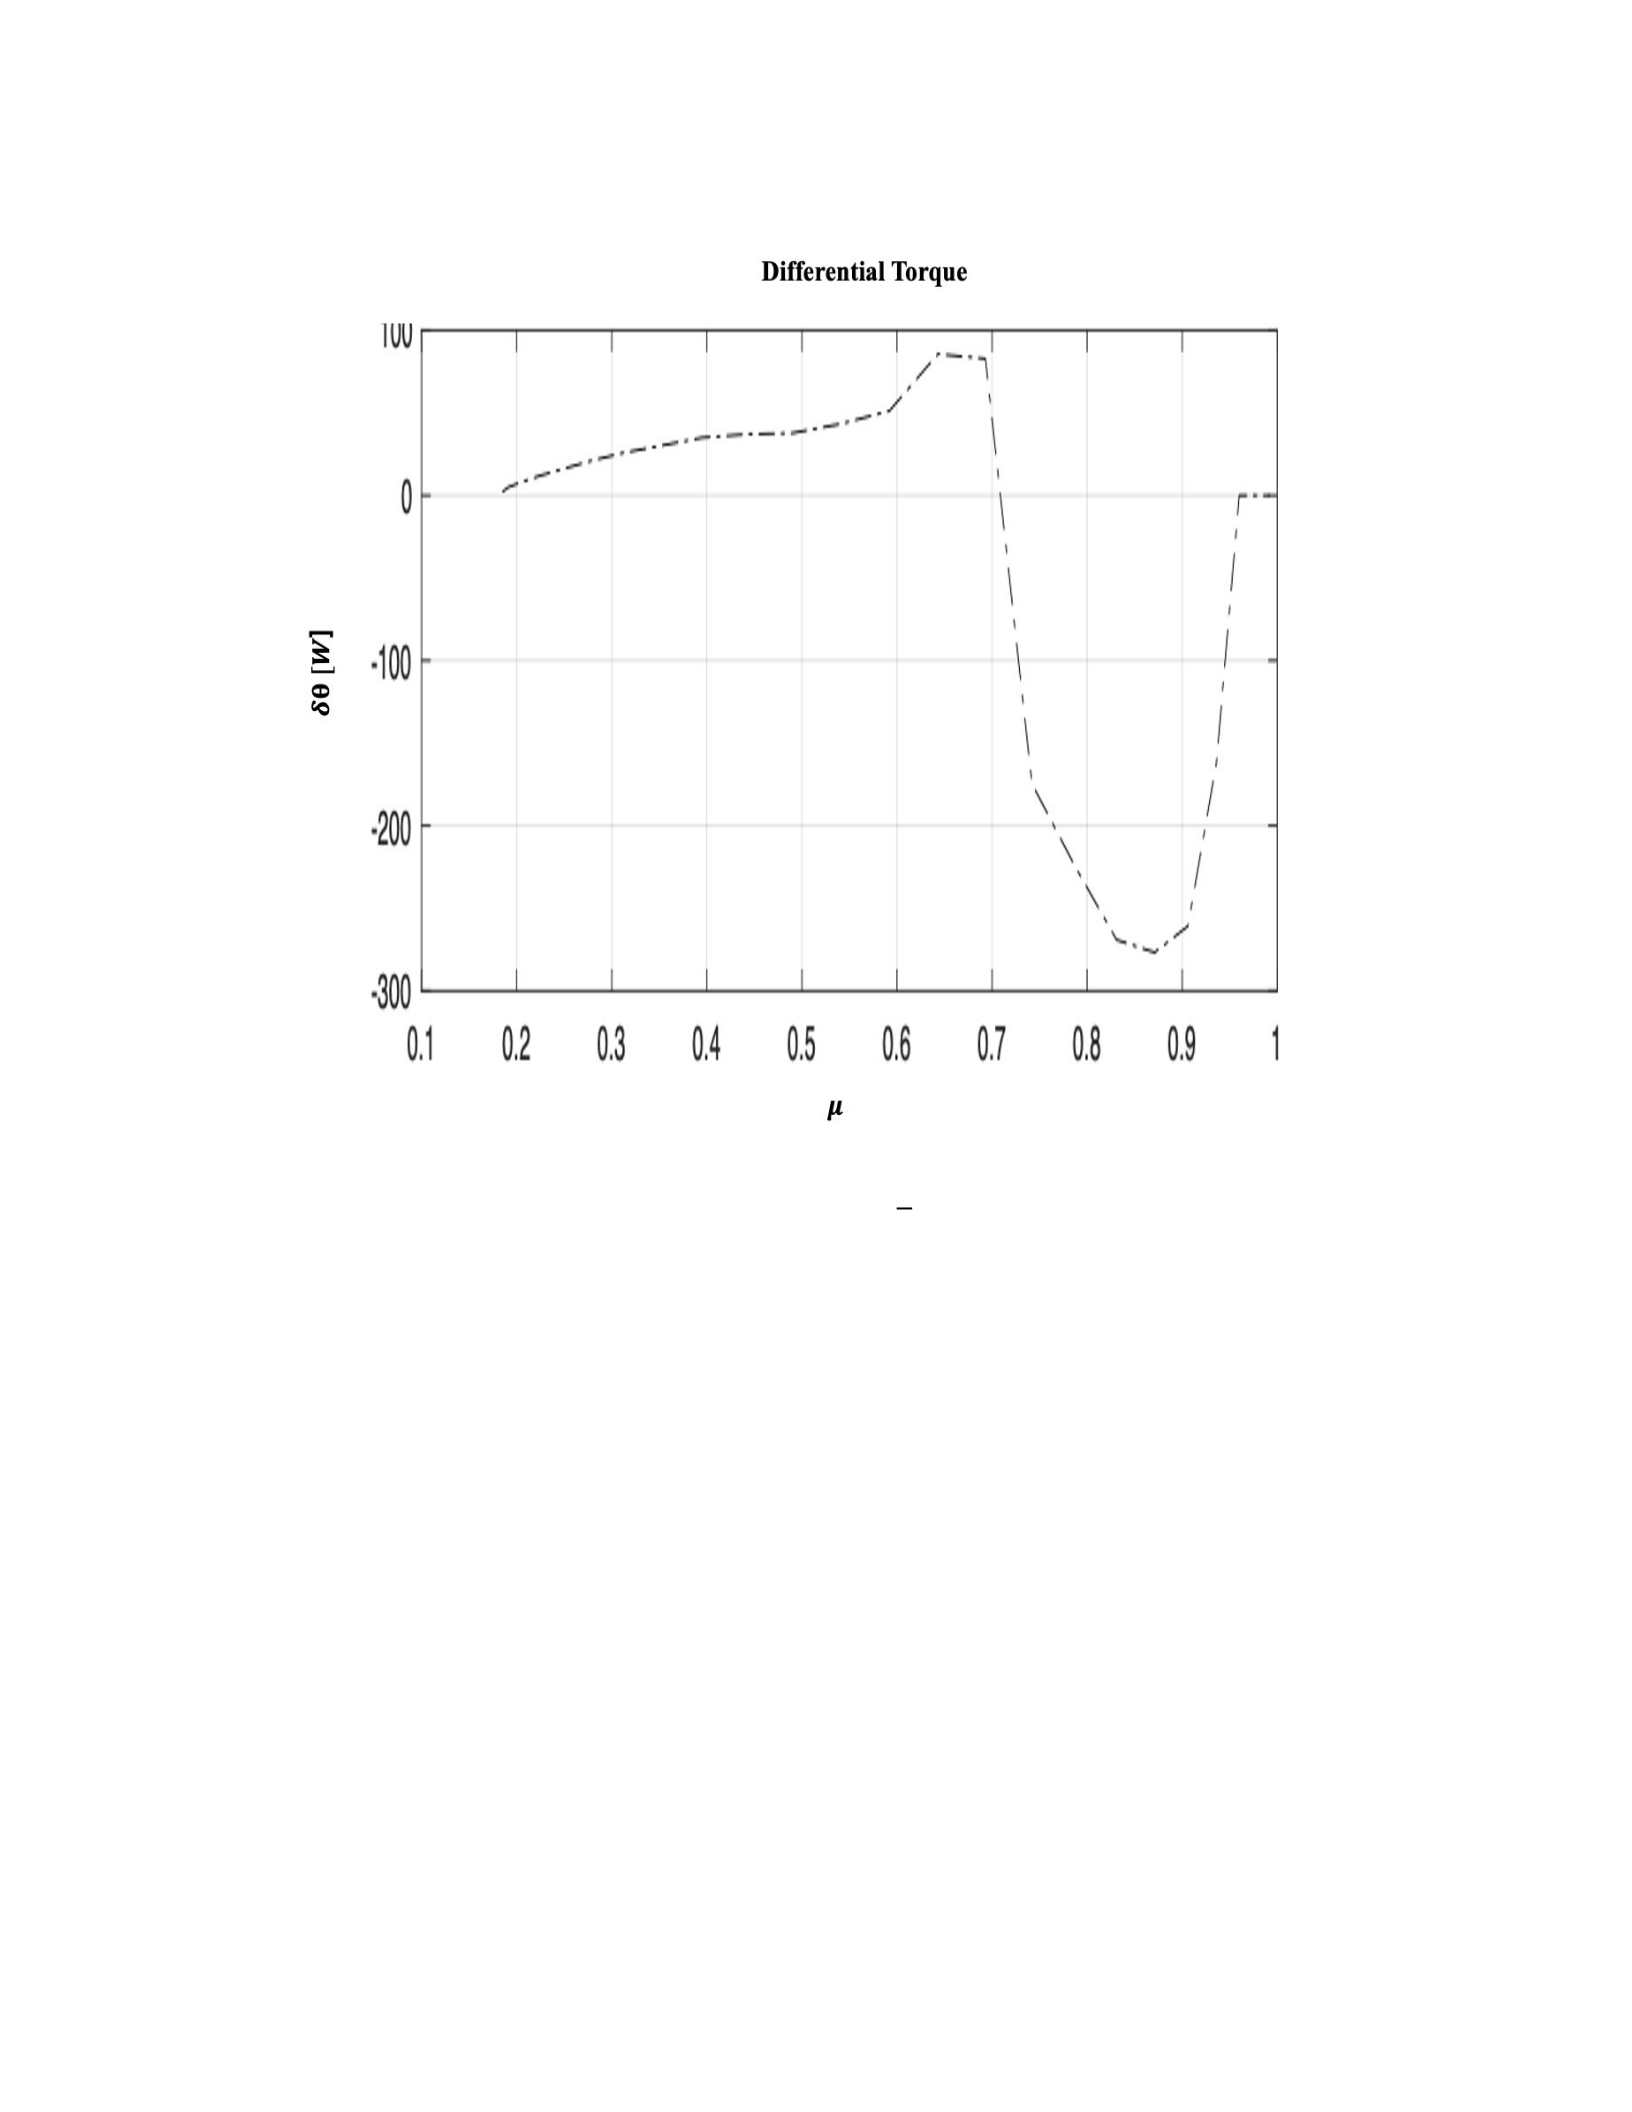
77
Figure 4.9 Differential Torque vs. r in full-size OCT
𝑅
Figure 4.9 shows "Differential Torque vs. r/R" in the context of OCT (Ocean Current Turbine)
representing the variation of differential torque along the radial position (r) relative to the rotor
radius (R) of the turbine. This graph is an important aspect of the analysis and design of ocean
current turbines, which utilize the kinetic energy of ocean currents to generate electricity.
Differential torque refers to the difference in torque acting on the rotor blades of an OCT as a
function of their radial position. Torque is the rotational force applied to the rotor, which is
essential for driving the generator and generating electric power.
Engineers analyze and design ocean current turbines to optimize differential torque distribution
along the range of rotor blades. The goal is to maximize torque generation efficiency while
minimizing the risk of structural fatigue and load on rotor components. Differential torque is
affected by the design of the rotor blades, including their shape, rotation distribution, and angle
of attack. Adjustments in the blade design are made to ensure that the blade operates at the
optimal angle of attack for efficient energy conversion. The differential torque must be carefully
managed to ensure that the force acting on the rotor blades is balanced. Imbalance
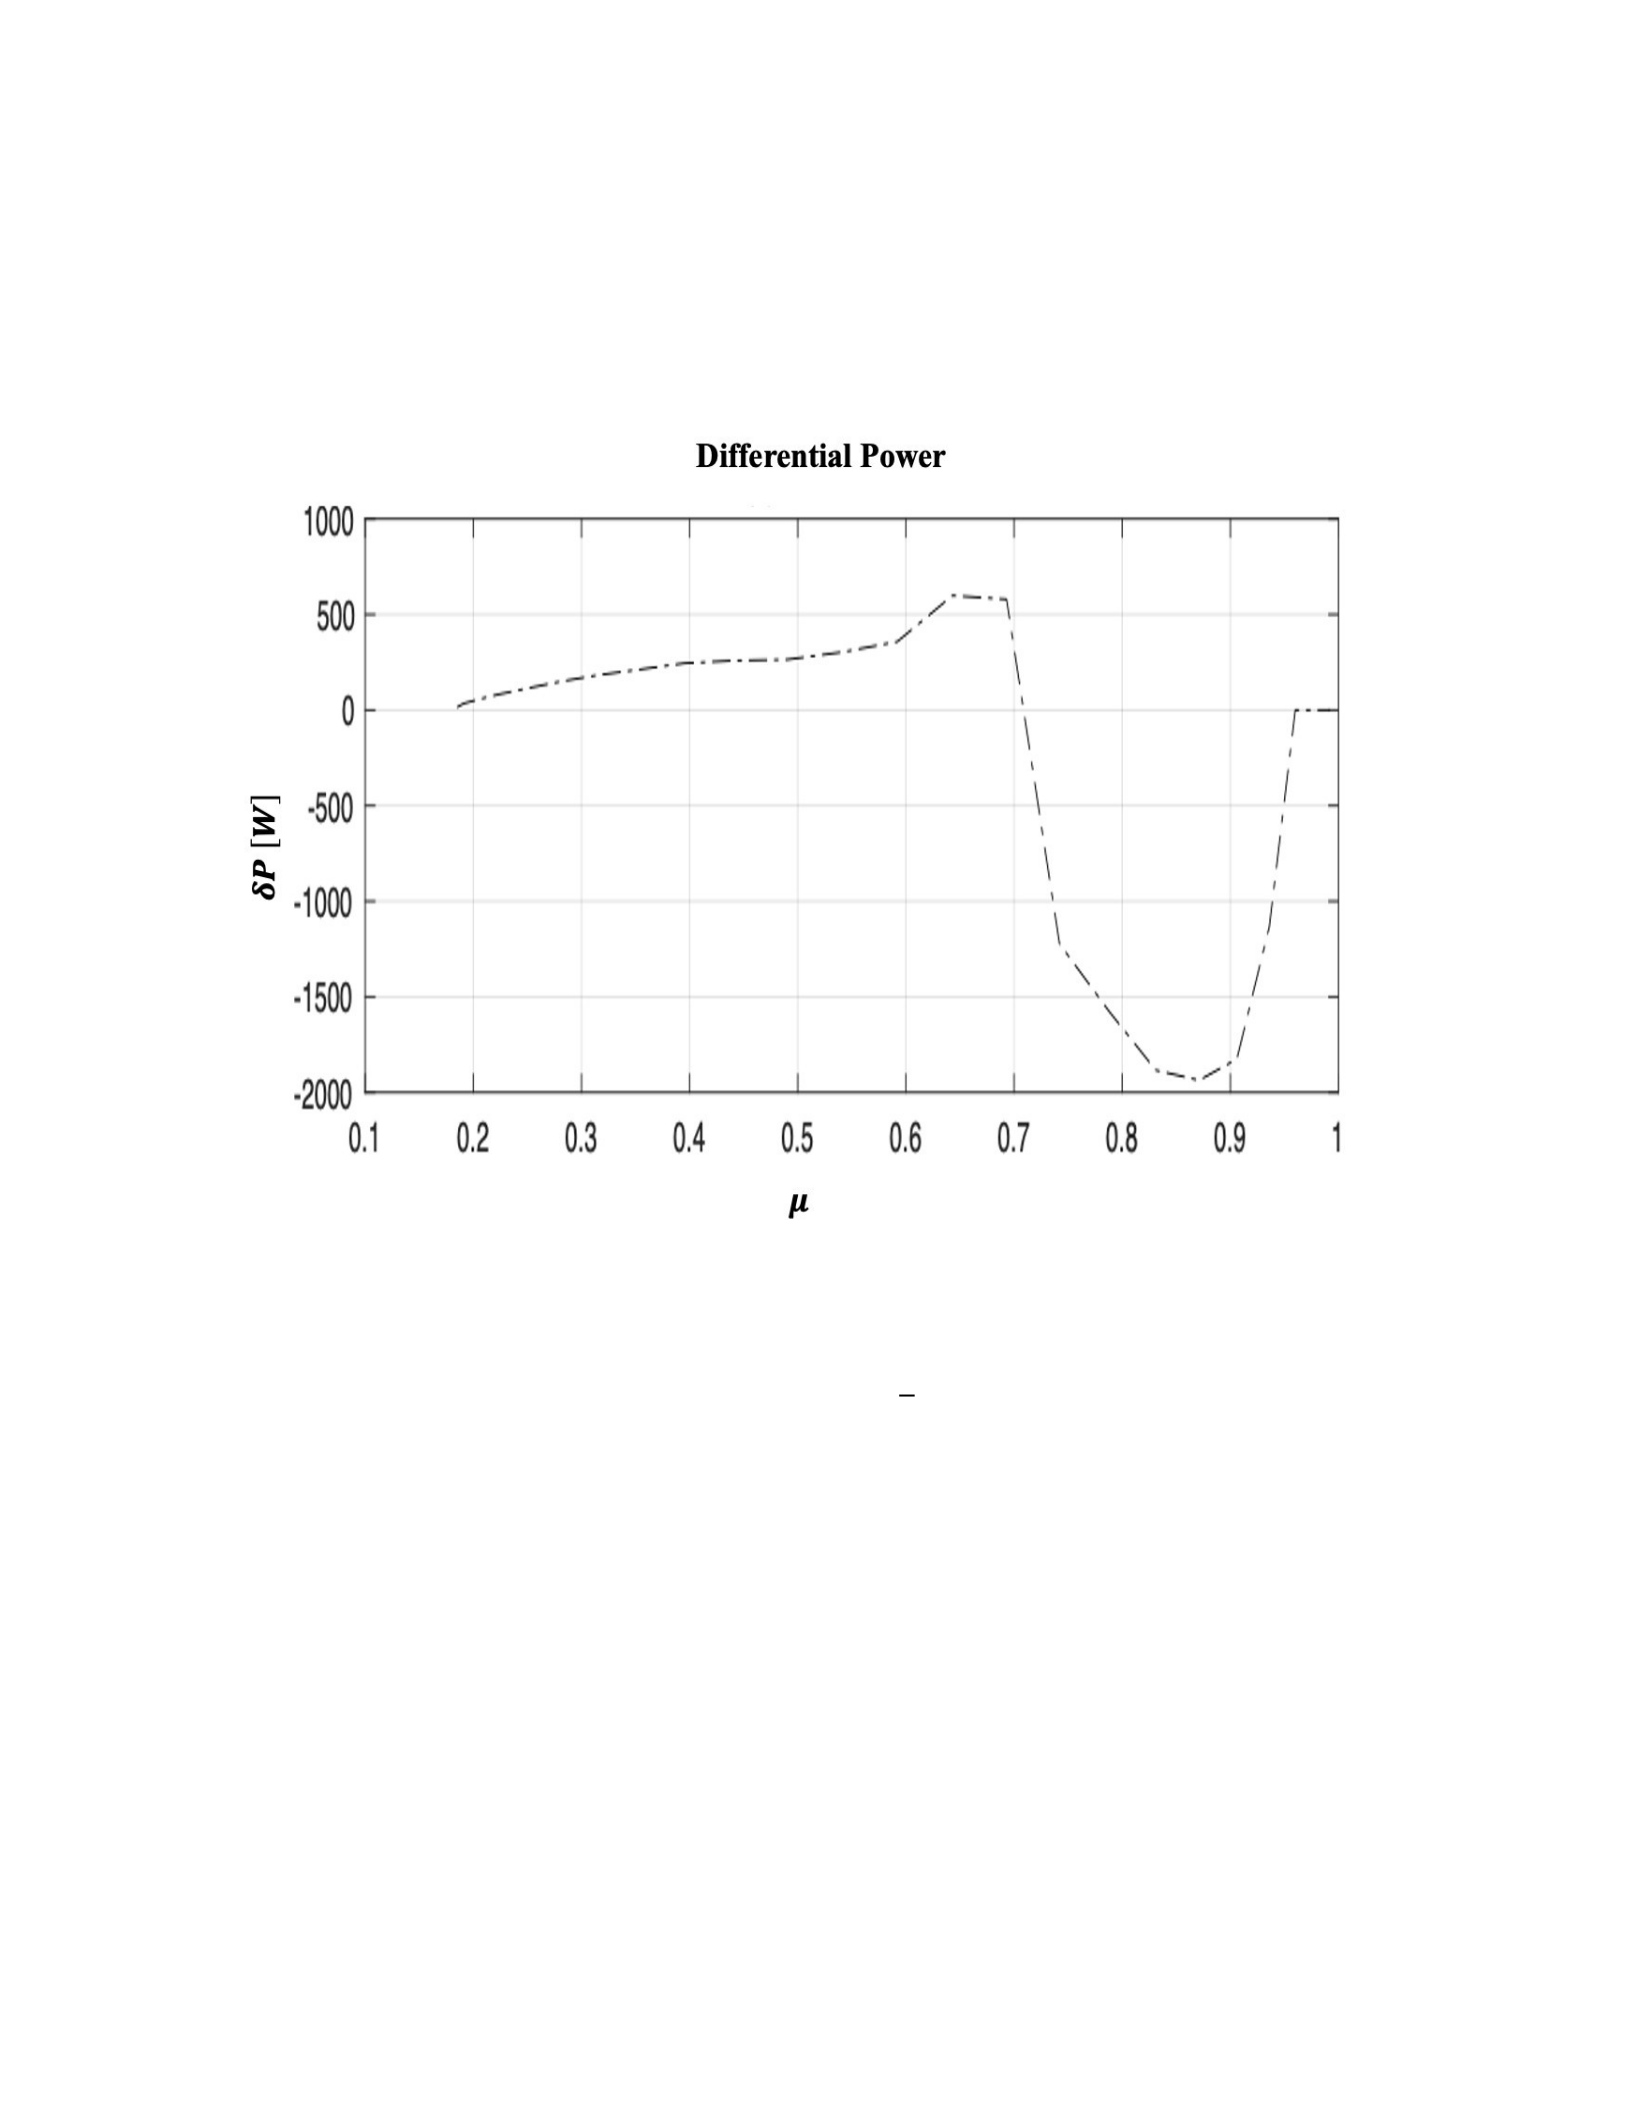
78
in torque distribution can cause problems such as blade fatigue, vibration, and decreased
turbine efficiency.
Figure 4.10 Differential Power vs. r in full-size OCT
𝑅
The "Differential Power vs. r/R" graph in the context of a full-size Ocean Current Turbine
(OCT) represents the variation in differential power output along the radial position (r) relative
to the rotor radius (R) of the turbine. Differential power refers to the difference in power output
produced by different parts of the rotor blade as a function of their radial position. Power, in this
context, is the rate at which energy is produced and is usually measured in watts (W) or kilowatts
(kW). The goal is to maximize the overall power output of the turbine while ensuring the
efficient use of available kinetic energy in ocean currents. The design of the rotor blades,
including their shape, rotation distribution, and angle of attack, play a crucial role in determining
the differential power distribution. We need to adjust the blade design parameters to ensure that
the blade operates at the optimal angle of attack for efficient energy conversion. Balancing the
power plant along the blade range is essential to prevent overloading or underutilizing certain
parts of the rotor. Imbalances in power plants can lead to problems such as
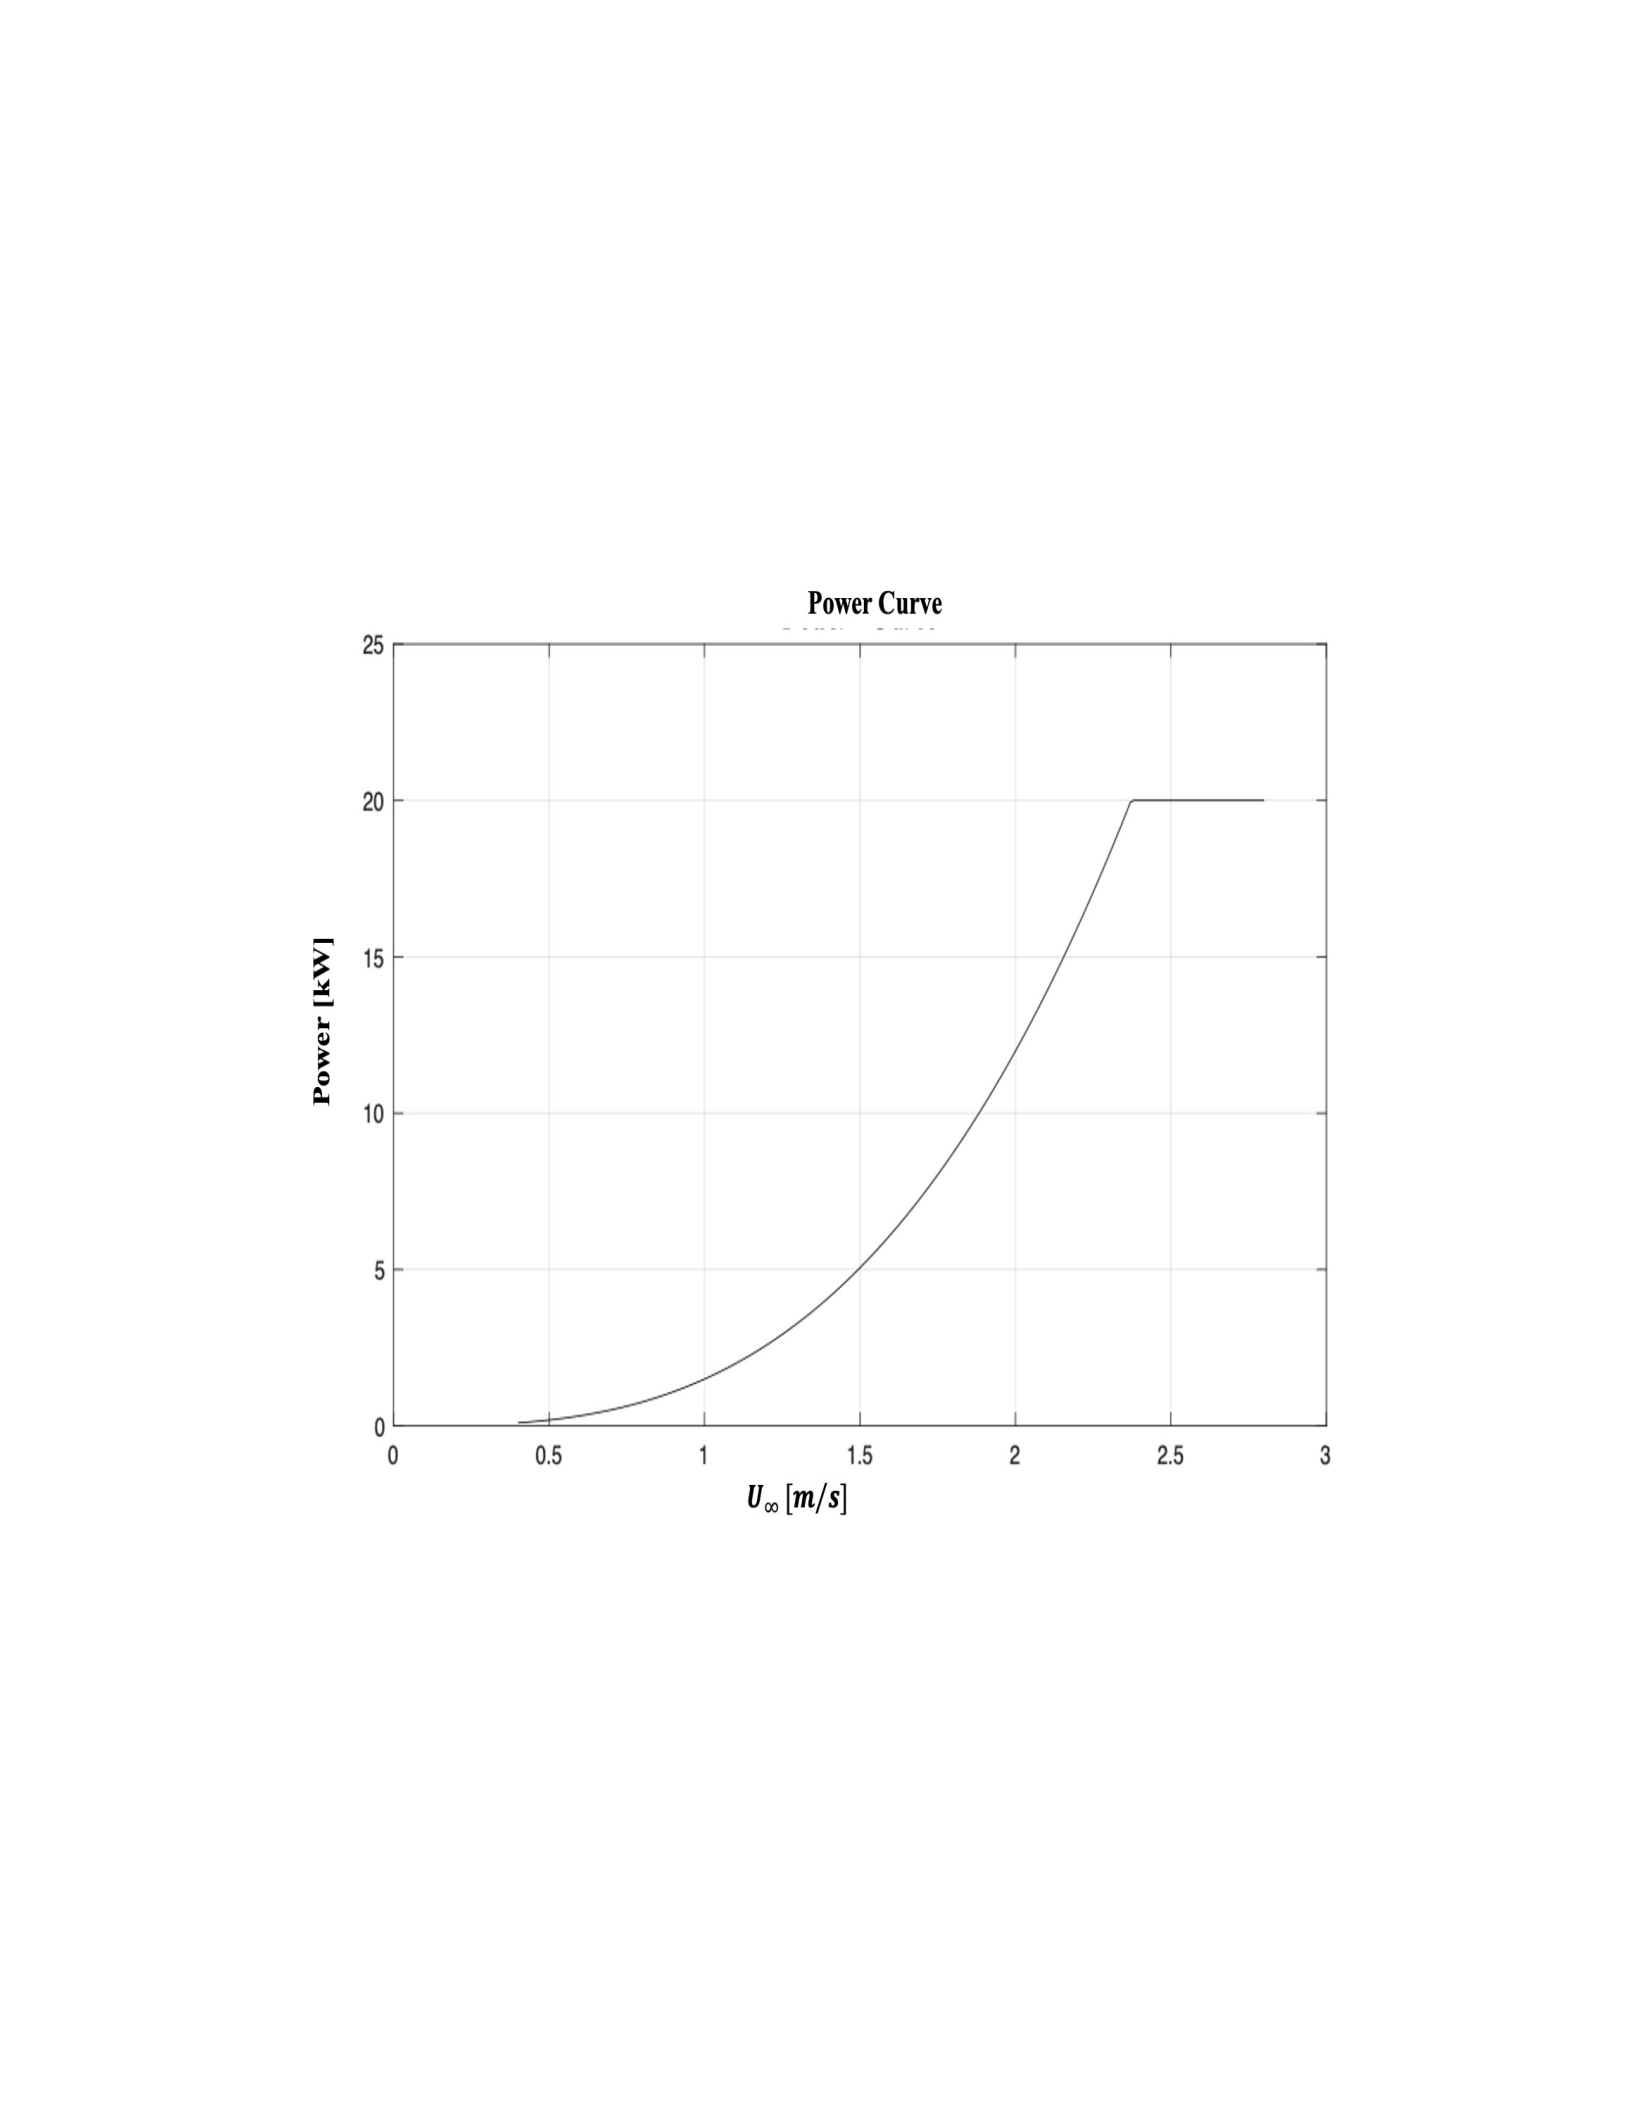
79
structural fatigue, reduced turbine efficiency, and uneven wear on turbine components.
Understanding the differential power distribution is critical during the OCT deployment resource
assessment phase. It informs decisions about turbine design, location, and network integration. In
practice, marine current turbines can be equipped with a control system that continuously
monitors and adjusts the rotor pitch angle or rotor speed to maintain efficient power generation
across the entire blade span, even under a variety of flow conditions.
Figure 4.11 Maximum Power Curve vs. Current Speed in full-size OCT
Figure 4.11 shows the "Maximum Power Curve vs. Current Speed" in the context of a full-size
Ocean Current (OCT) Turbine depicting the relationship between the turbine's maximum power
output and the ocean current velocity.
According to our BEM code, the maximum rotor power coefficient for the turbine is
Cp=0.4390, which is close to the predicted maximum rotor power
coefficient
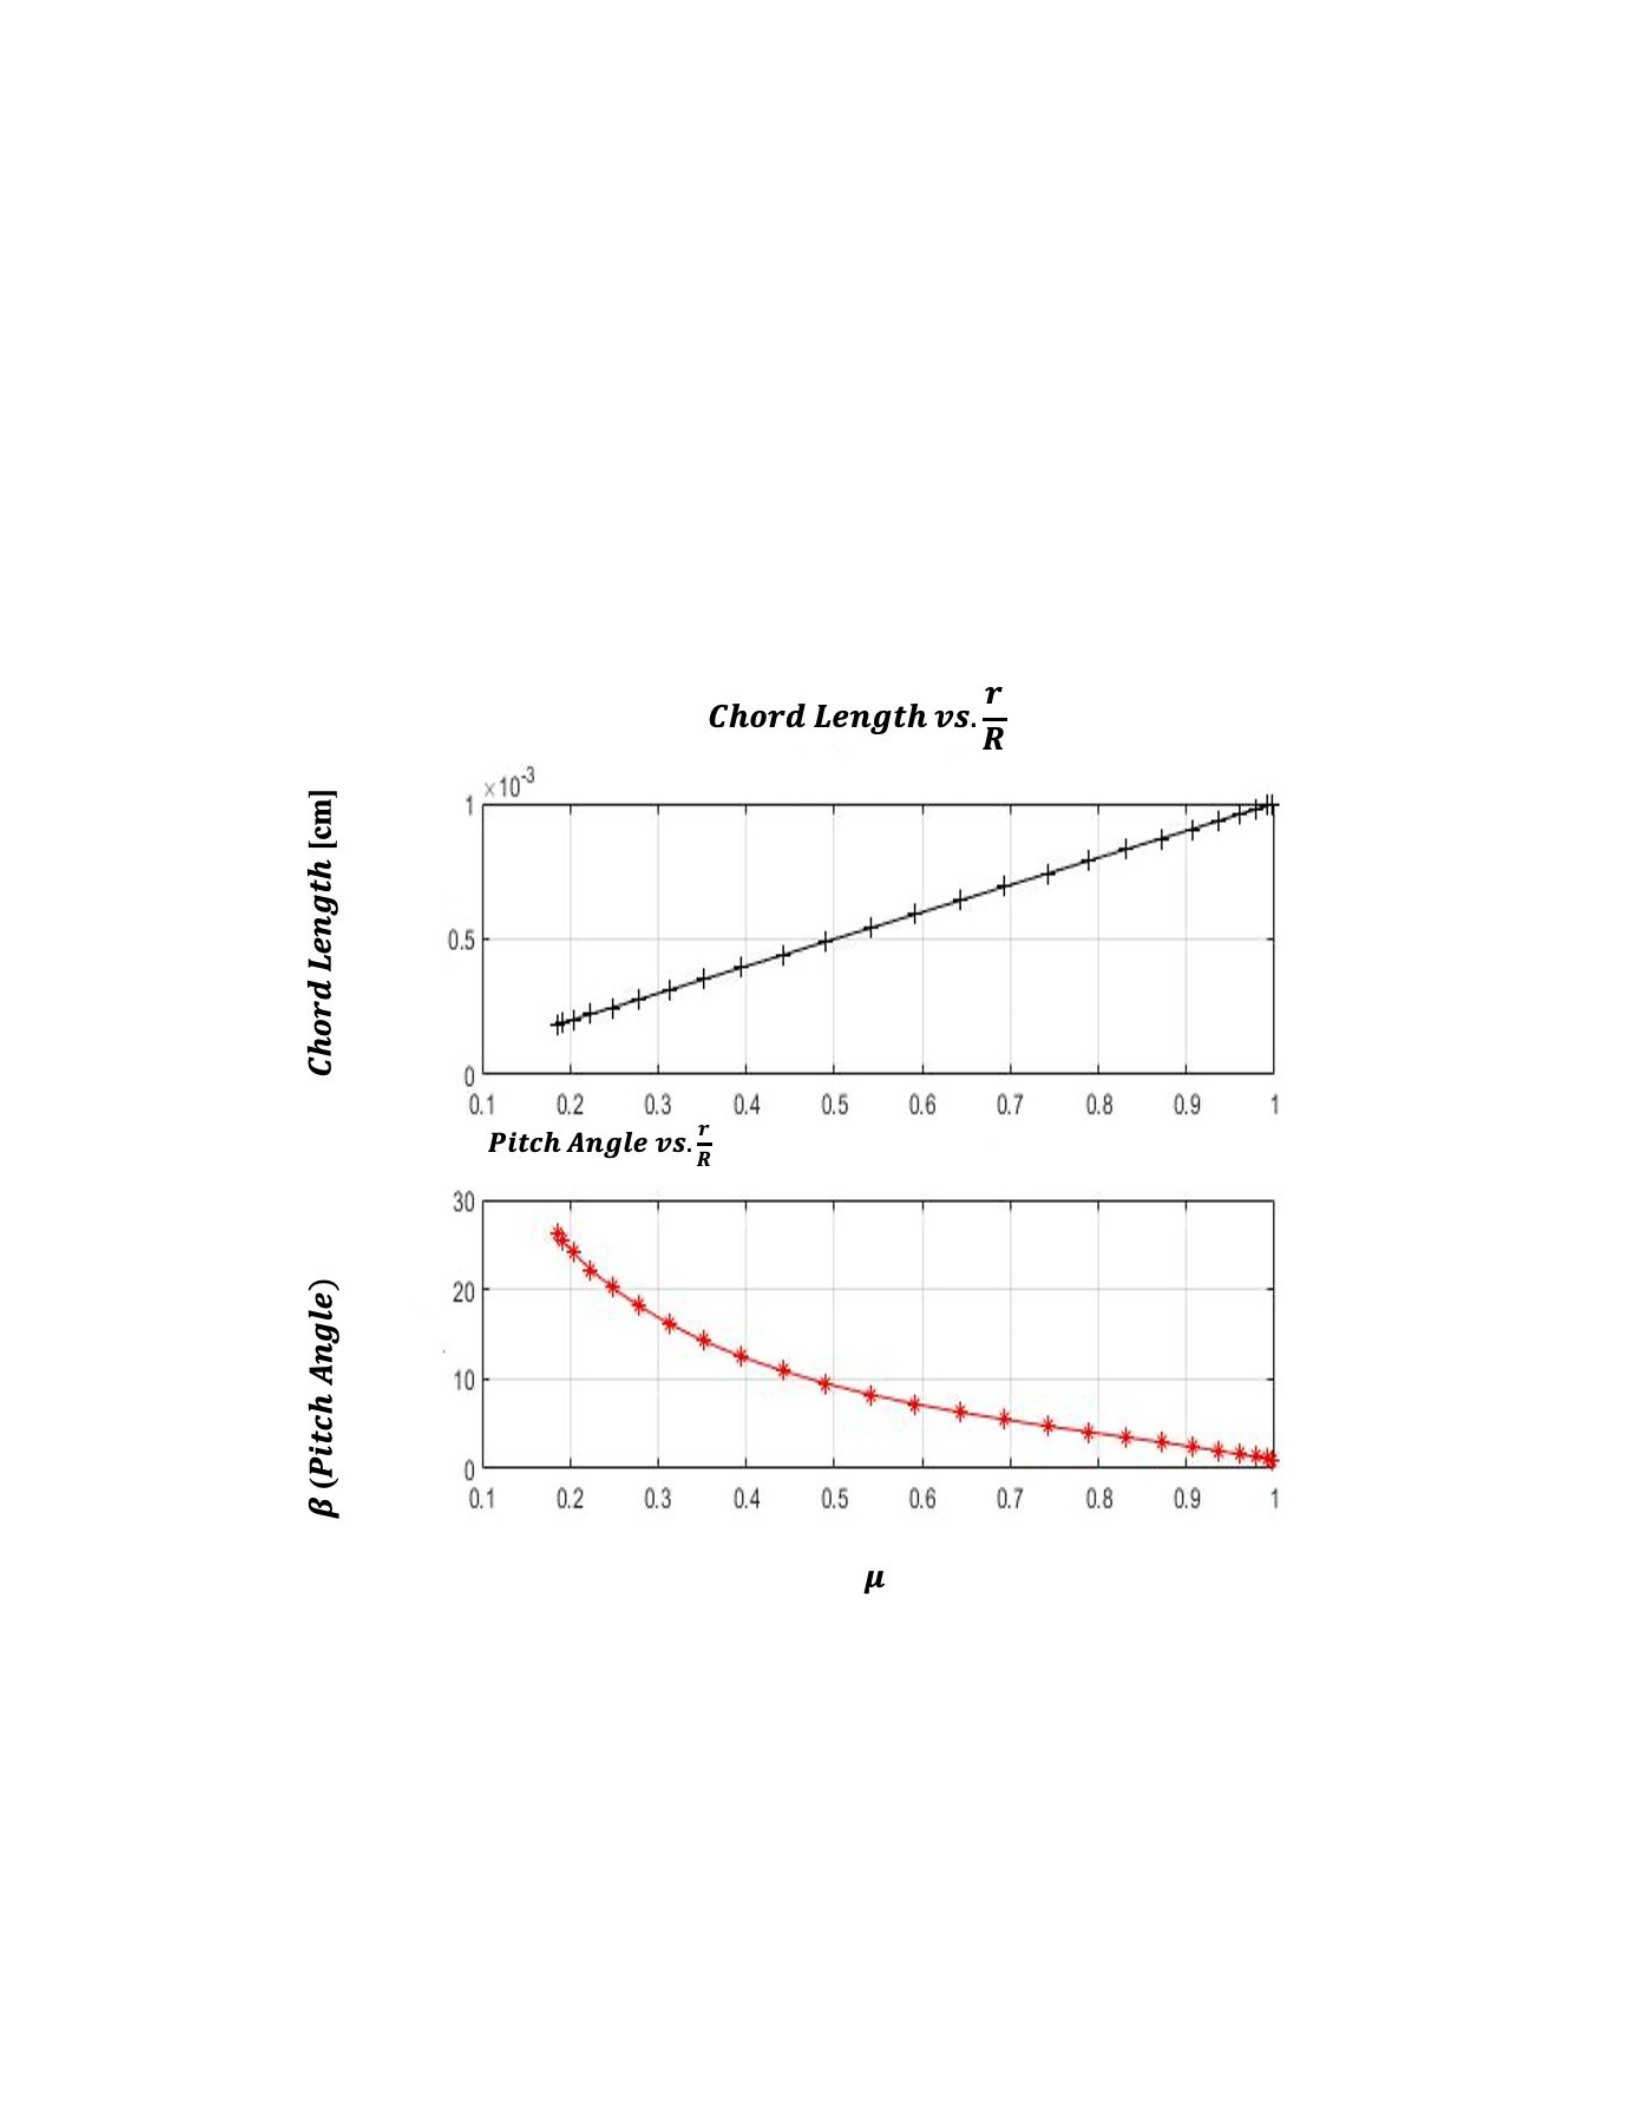
80
Cp=0.45 was done by James H. VanZwieten, Jr., Nicolas Vanrietvelde, and Basil L.
Hacker, Student Member, IEEE, Numerical Simulation of an Experimental Ocean Current
Turbine [74]. Ocean current measurements were taken off the coast of Southeast Florida (Lat:
26°04.3'N, Lon: 79°50.5'W) over a 13-month period from February 2009 to March 2010
[74.93]. These measurements show that the average current velocity at a depth of 25 m is 1.6
m/s, with a range between 0.4 and 2.5 m/s. [94, 95]. Figure 15 shows the maximum power curve
of a marine current turbine for different current speeds. The maximum power is considered to be
20kw based on [74, 93, 95].
Figure 4.12 CHORD LENGTH AND PITCH ANGLE VS.
r;R
for small-scale OCT

81
The pitch angle and chord length are two important factors in blade design that impact the
blade's ability to rotate. The pitch angle is the angle at which the blade is oriented with respect to
the plane of rotation, while the chord length is the distance between the front and back edges of
the blade. Figure 4.12 shows the chord length and pitch angle as a function of the radial distance
from the center of the bar, expressed as a fraction of the blade radius, or r/R. Chord length vs.
plot r/R shows the variation in chord length along the bar. The length of the chord is usually
greater near the root of the blade, where more lift is required to support the weight of the blade
and rotor, and decreases towards the tip of the blade, where less lift is required. This variation in
chord length helps to optimize the aerodynamic performance of the blade by ensuring that the
optimal distribution of lift power is carried out throughout the blade span. Similarly, the pitch
angle vs. r/R plot shows the variation in pitch angle along the blade. The pitch angle is usually
larger near the root of the blade, where more torque is required to overcome the rotor resistance,
and downhill towards the tip of the blade, where less torque is required.
This variation in pitch angle helps to optimize the aerodynamic performance of the blade by
ensuring that the angle of attack is optimal across the entire blade span. (96,97,98).
4.3 Comparison of the first round of BEM experiments and simulations:
The careful manufacturing process of hydrokinetic turbine nacelle involves the advanced
application of additive manufacturing technology, especially the use of the Prusa i3 MK3S+ 3D
printer. This advanced 3D printing technology was chosen for its exceptional precision, speed,
and reliability. Nacelle, a critical component of a hydrokinetic turbine, undergoes rigorous
engineering considerations to ensure its durability and structural integrity, especially under
anticipated forces and pressures during test scenarios. The most important decision in the
manufacturing process is the selection of suitable materials that can withstand harsh underwater
testing conditions. The choice falls on polyethylene terephthalate glycol-changed (PETG)
filaments, a thermoplastic known for its exceptional strength, durability, and resistance to
environmental factors. PETG has emerged as the preferred material for 3D printing in
demanding applications due to its ability to maintain structural integrity under a variety of
conditions. Its characteristics make it particularly suitable for deployment in harsh
environments, such as those encountered in submerged test scenarios.
The spread of PETG filaments in the 3D printing process is essential for several reasons. PETG
is praised for its high strength and impact resistance, providing the model with the sturdiness
necessary to withstand the dynamic forces it will experience during testing. In addition, PETG
exhibits excellent chemical resistance, ensuring that it remains unaffected by the corrosive
properties of water and other environmental elements. Resistance to these chemicals is
especially important in underwater applications, where exposure to different water compositions
and contaminants is inevitable. The inherent transparency of PETG further eases the
manufacturing process, allowing for visual inspection during and after 3D printing. This
transparency is invaluable for quality control, allowing engineers to identify potential problems,
irregularities, or imperfections in the printing process. This improves the reliability of the
overall manufacturing process, ensuring that the final product meets the stringent standards
required for accurate testing. After completing the 3D printing phase, additional steps are taken
to fortify the hydrokinetic turbine model and provide it with waterproof properties. Recognizing
the critical nature of the maintenance of waterproof structures for underwater

82
application, the entire model undergoes a careful coating process using epoxy resin. Epoxy, a
thermoset polymer known for its adhesive and sealing properties, was chosen for its
effectiveness in providing an additional layer of protection against potential water damage
during testing.
The epoxy coating has a dual purpose in improving the durability of hydrokinetic turbine
models. Firstly, it acts as a strong adhesive, bonding the 3D-printed layers of PETG filament
together, reinforcing the overall structural integrity of the model. Second, and perhaps more
critical for underwater testing, epoxy forms a continuous, impermeable layer over the surface of
the model. This coating effectively seals existing gaps or openings, preventing water infiltration
and protecting internal components from potential damage. The strategic application of epoxy
coatings, with the dual benefits of structural reinforcement and water sealing, is a testament to
the meticulous attention to detail in the development of hydrokinetic turbine models. The choice
of epoxy as a coating material is guided by its compatibility with PETG and its proven
effectiveness in providing a protective barrier against environmental elements.
The integration of 3D printing technology, PETG filaments, and epoxy coatings is a
comprehensive approach to the creation of hydrokinetic turbine models that not only withstand
the rigors of submerged testing but also provide reliable and consistent performance. Each
component of this manufacturing process contributes to the overall durability, strength, and
waterproof properties of the model, ensuring its readiness for real-world testing scenarios.
The synergy between 3D printing technology and advanced materials such as PETG and epoxy
is a hallmark of contemporary engineering practice. The precision provided by 3D printing
allows for intricate designs and complex geometries, giving engineers the flexibility to optimize
turbine models for efficiency and performance. The use of PETG, with its high strength and
chemical resistance, is aligned with the requirements of demanding hydrokinetic applications,
where components are subjected to varying water compositions and potential contaminants.
In addition, the epoxy coating not only adds a protective layer to the hydrokinetic turbine model
but also paves the way for customization. The coating process allows engineers to fine-tune the
surface properties of the model, affecting factors such as surface roughness and friction, which
can have implications for fluid dynamics during testing. This level of customization
demonstrates the sophistication of the manufacturing process and the attention to detail in
customizing the hydrokinetic turbine model for the right test scenario. The development of
hydrokinetic turbine models, which is characterized by the integration of 3D printing
technology, PETG filaments, and epoxy coatings, goes beyond conventional manufacturing
practices. It exemplifies a forward-thinking approach that leverages cutting-edge technologies
and materials to create robust and adaptable models for hydrodynamic testing. Hydrokinetic
turbine models, as a result of this meticulous manufacturing process, serve as more than just a
physical representation of the turbine. It turns into a powerful tool for conducting accurate and
reliable testing in an underwater environment. The choice of materials and the application of
advanced manufacturing techniques reflect a commitment to precision, durability, and versatility
– essential qualities for any equipment that experiences hydrokinetic testing challenges.
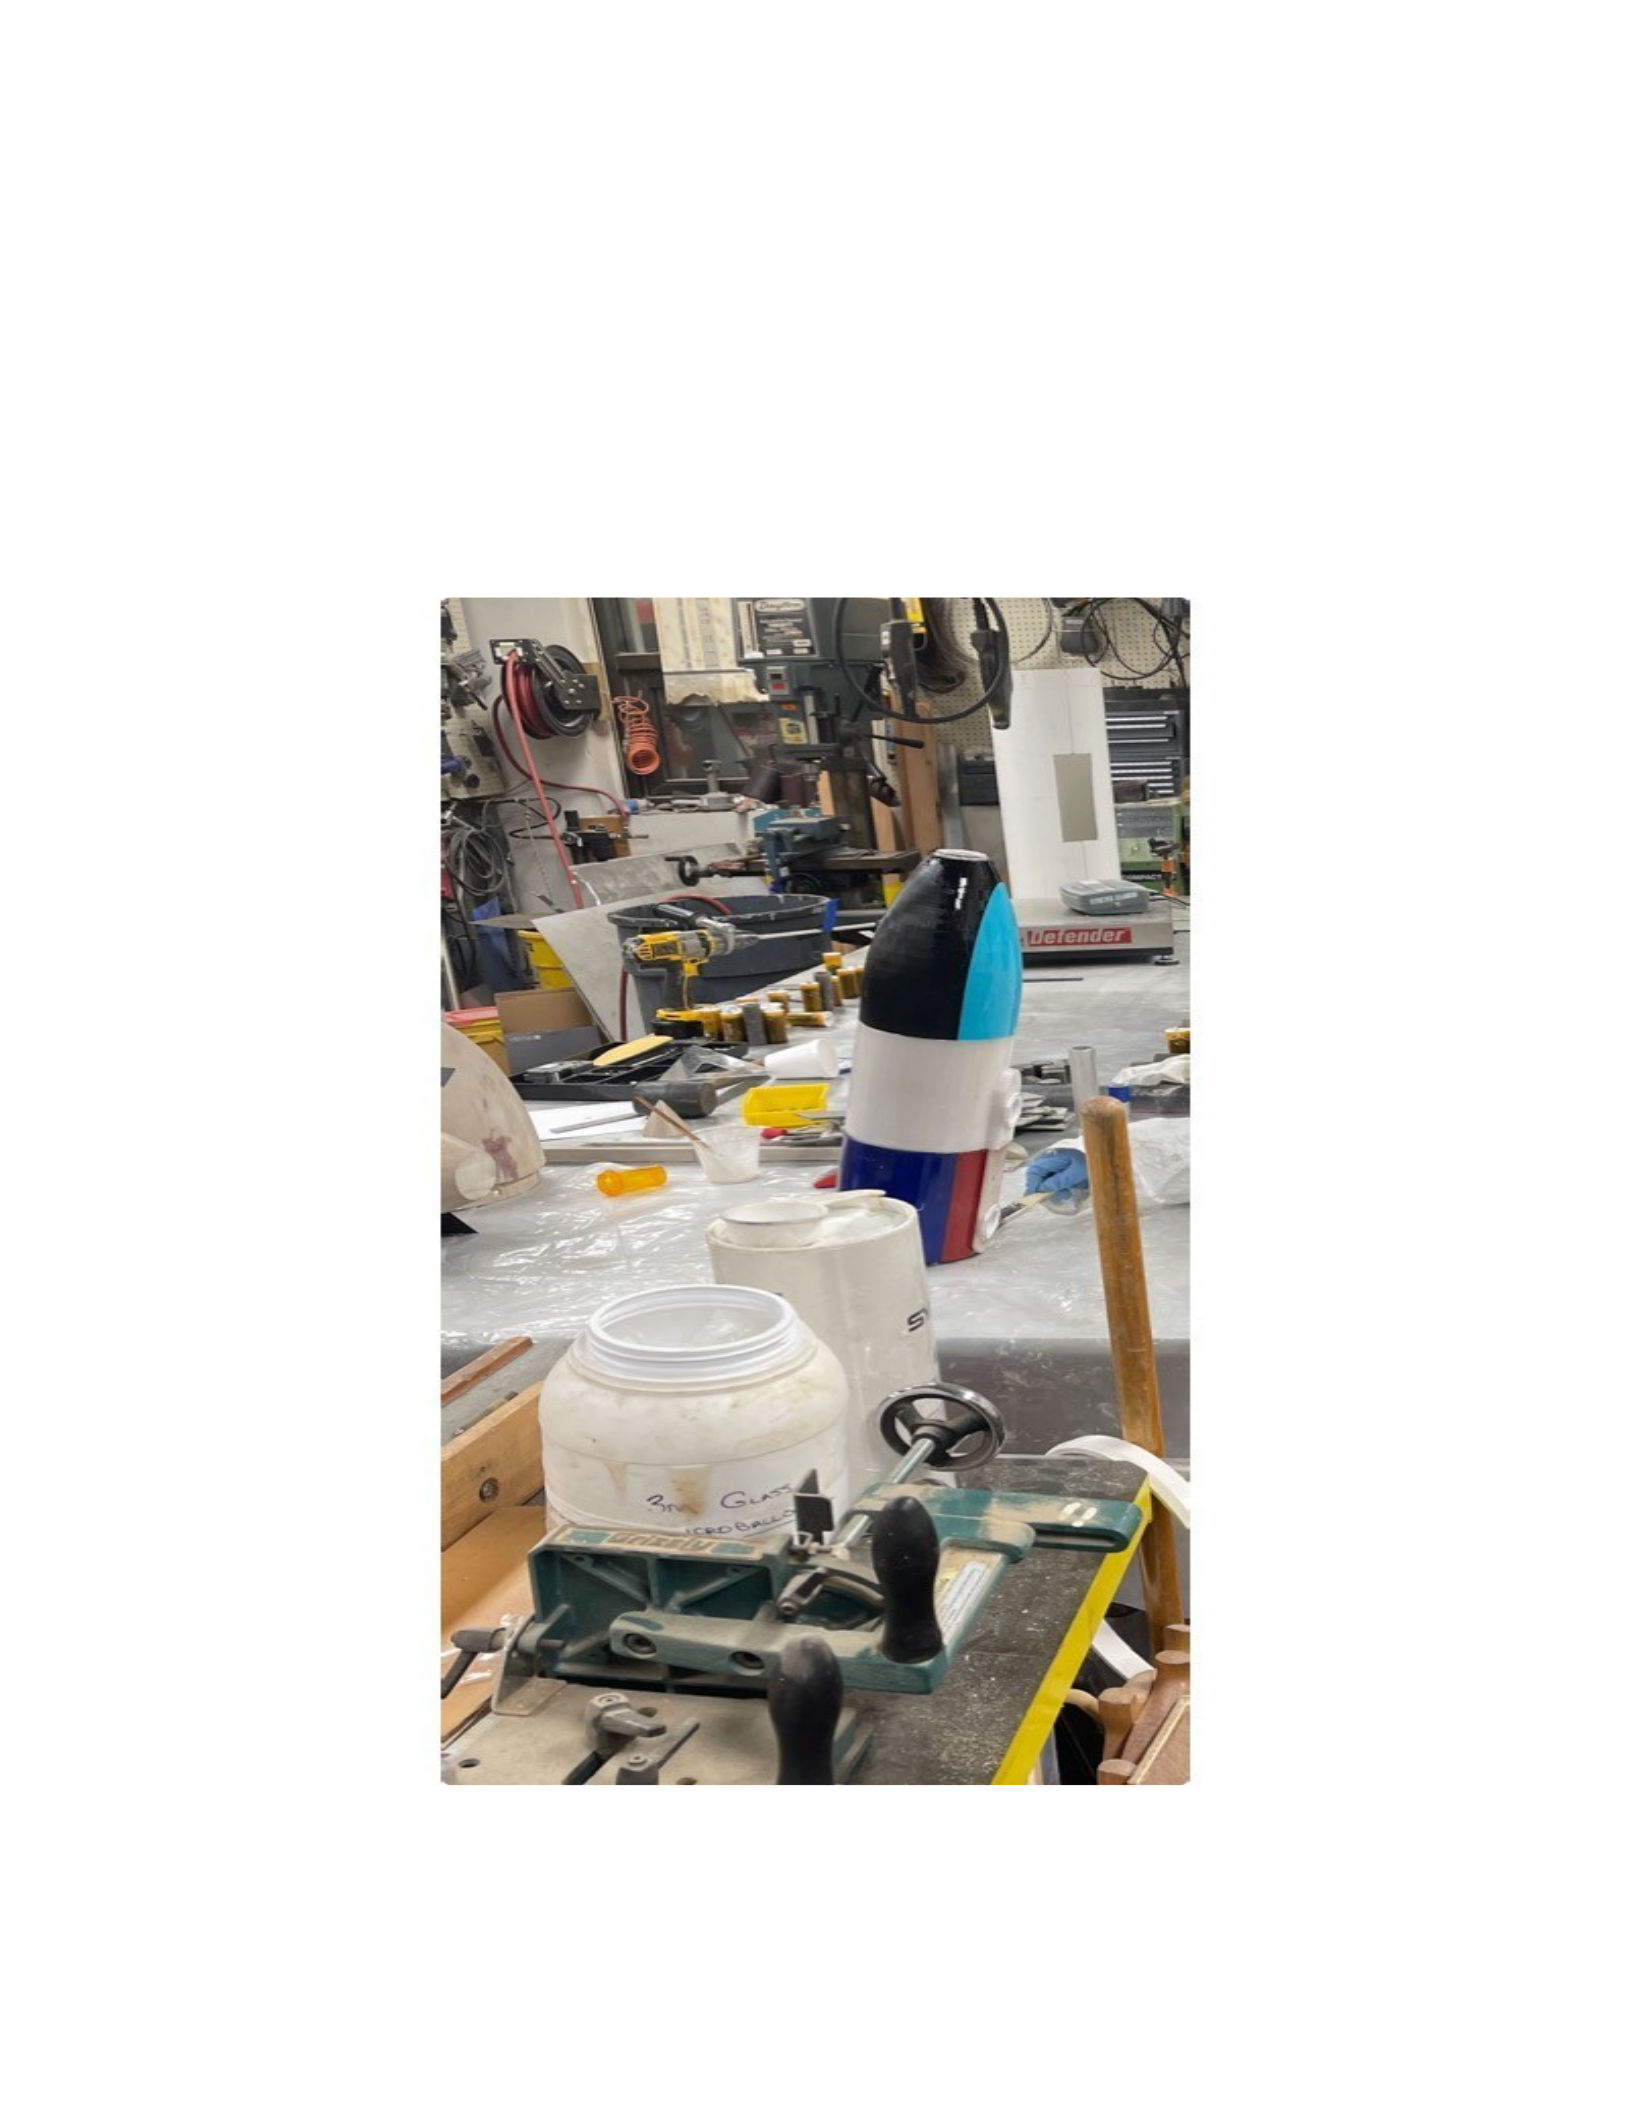
83
In conclusion, the development of hydrokinetic turbine models is a testament to the convergence
of innovations in 3D printing technology and the selection of strategic materials for challenging
applications. The use of Prusa i3 MK3S+ 3D printers, PETG filaments, and epoxy coatings is a
comprehensive approach to creating hydrokinetic turbine models that can withstand the rigors of
submerged testing. Not only does this model meet the standards required for structural integrity
and waterproofness, but it also displays the potential for customization and optimization for
specific test scenarios. This combination of technologies and materials underscores the
commitment to advancing the field of hydrodynamics through precision engineering and
thoughtful material selection, paving the way for more robust and reliable hydrokinetic testing in
the future.
Figure 4.13 Nacelle coated with epoxy.
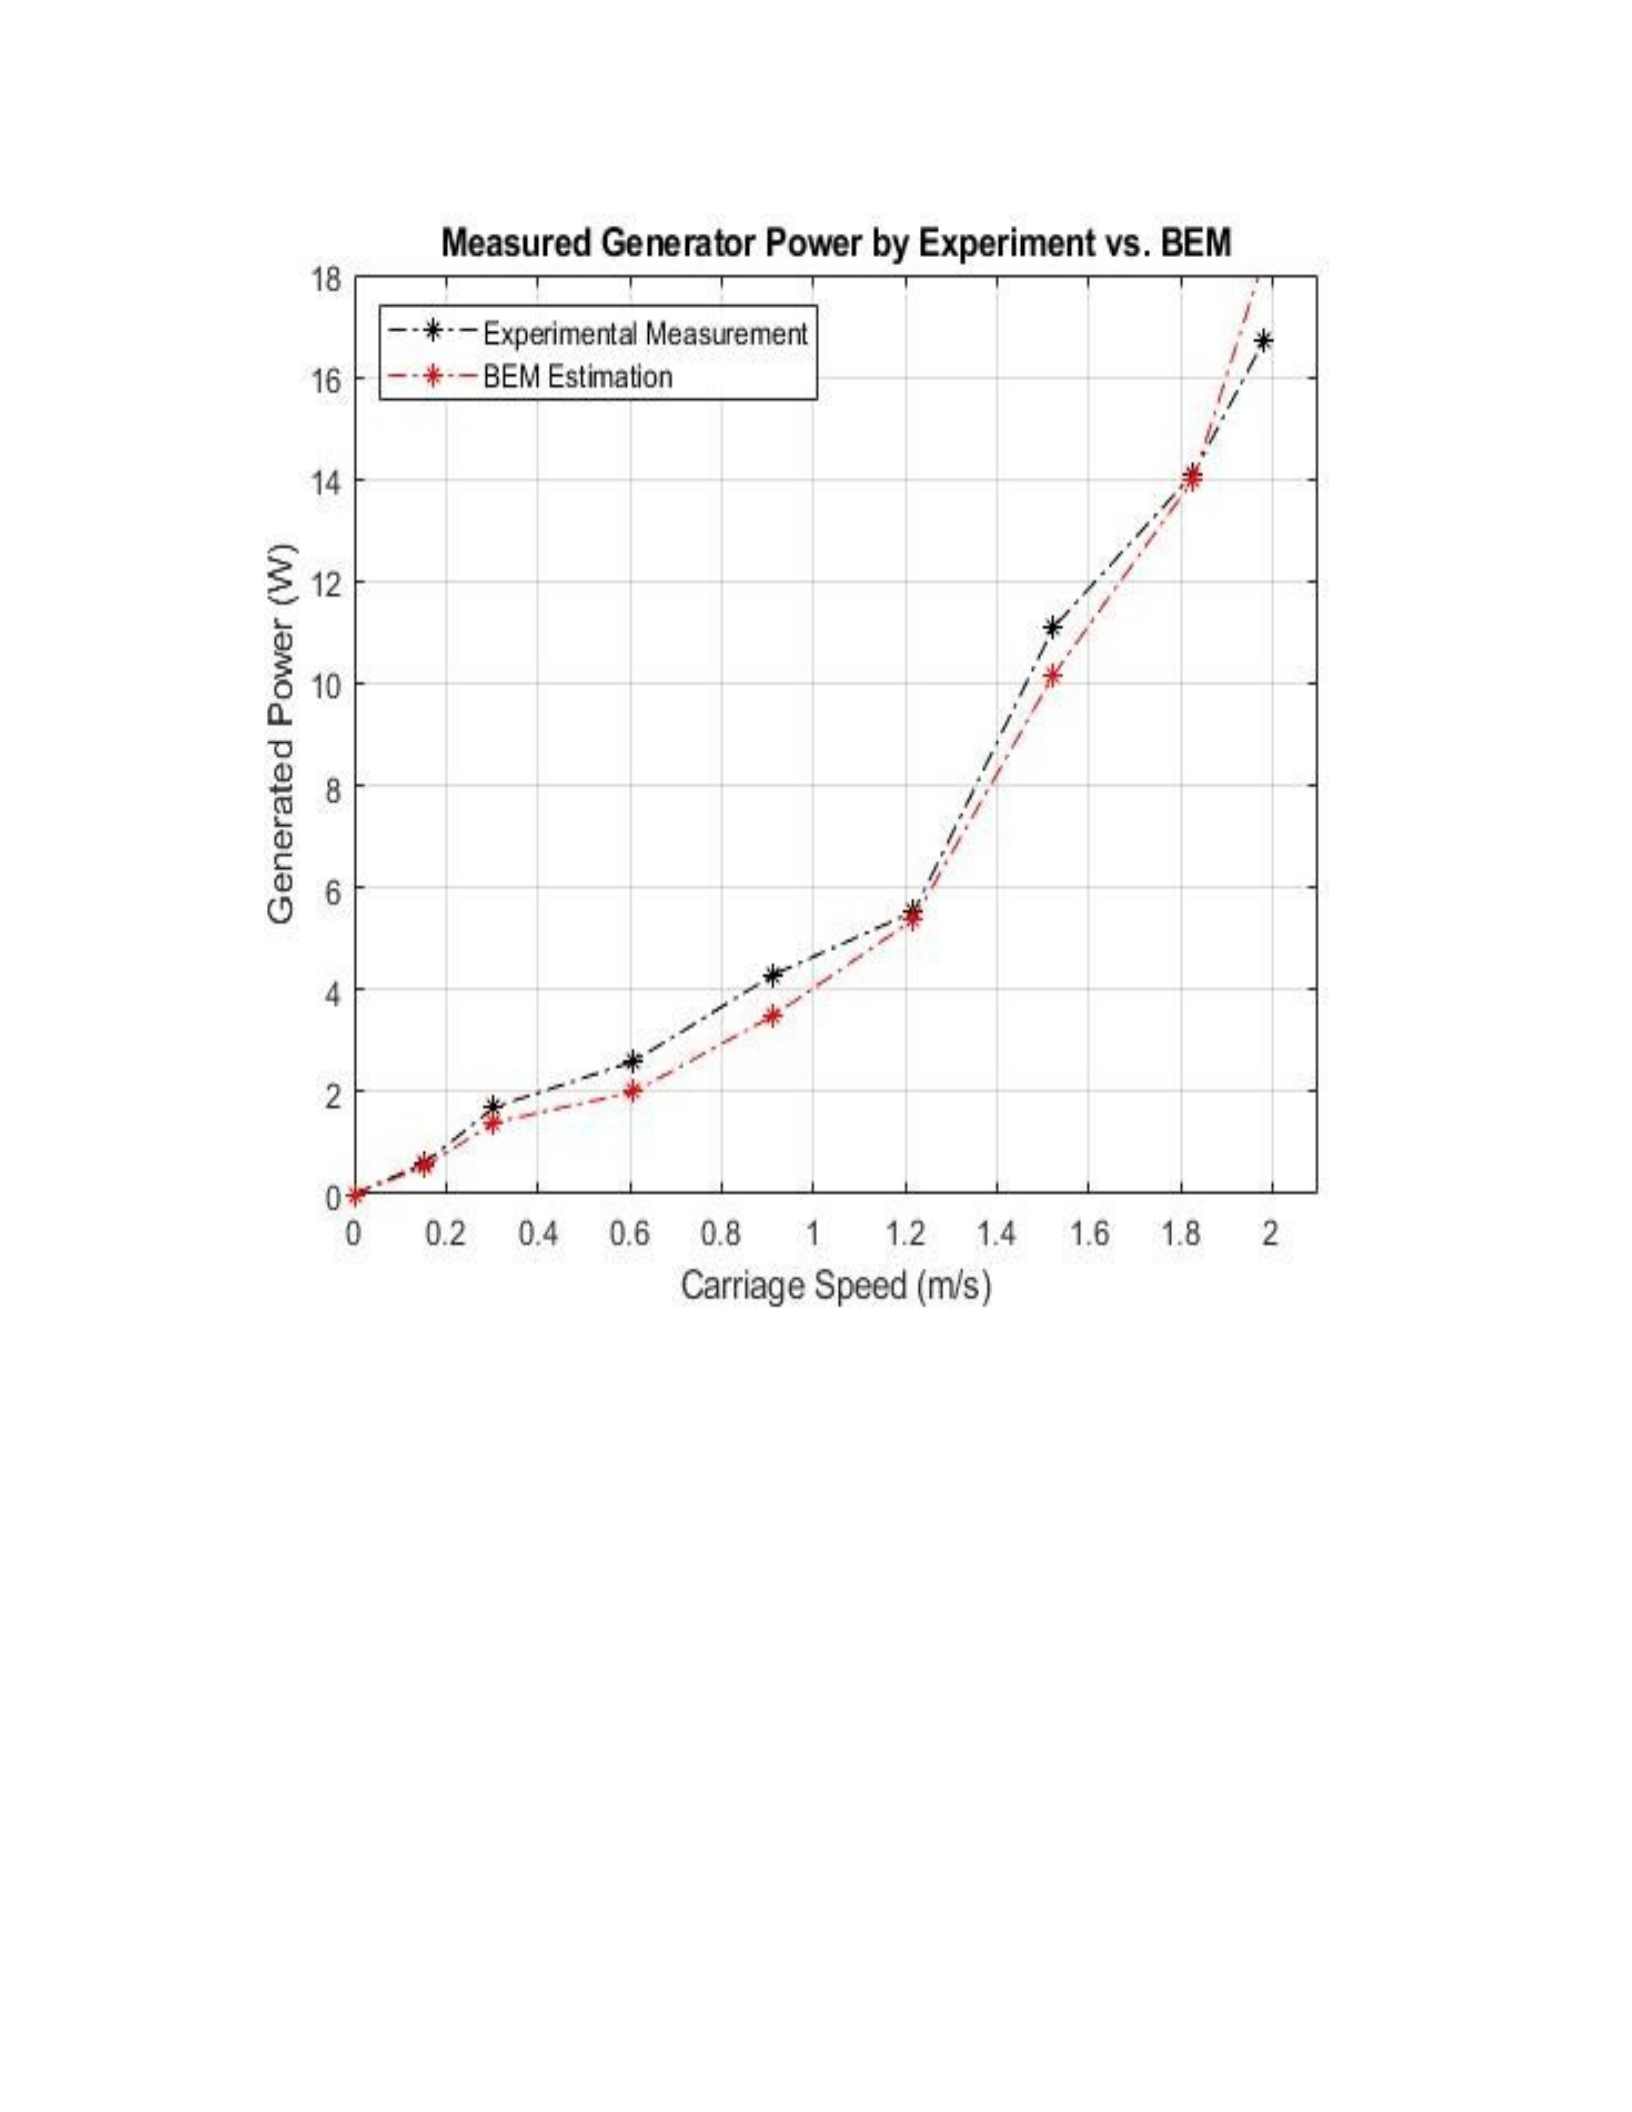
84
Figure 4.14 RESULTING TORQUE MEASURED BY EXPERIMENT VS. BEM FOR
SMALL-SCALE OCT
Figure 4.14 illustrates how, when the speed of the train is increased from 0 to 2 meters per
second (m/s), the average power produced changes. The power generated is an indicator of the
system's power output, which in an underwater current turbine converts the kinetic energy of
water into electrical energy. The plot findings from actual experiments and simulation of blade
element momentum (BEM) show that as the speed of the train increases, the power generated
also increases. This is expected because the faster the velocity of the fluid, the more energy is
available to be captured by the turbine blades (99,100,101). The plot shows that for train speeds
of up to 1.8 m/s, the power generated from the BEM simulation is slightly less than the
experimental results. This suggests that OCT performance may be somewhat underestimated by
simulations. The generated power anticipated by the BEM calculation is,
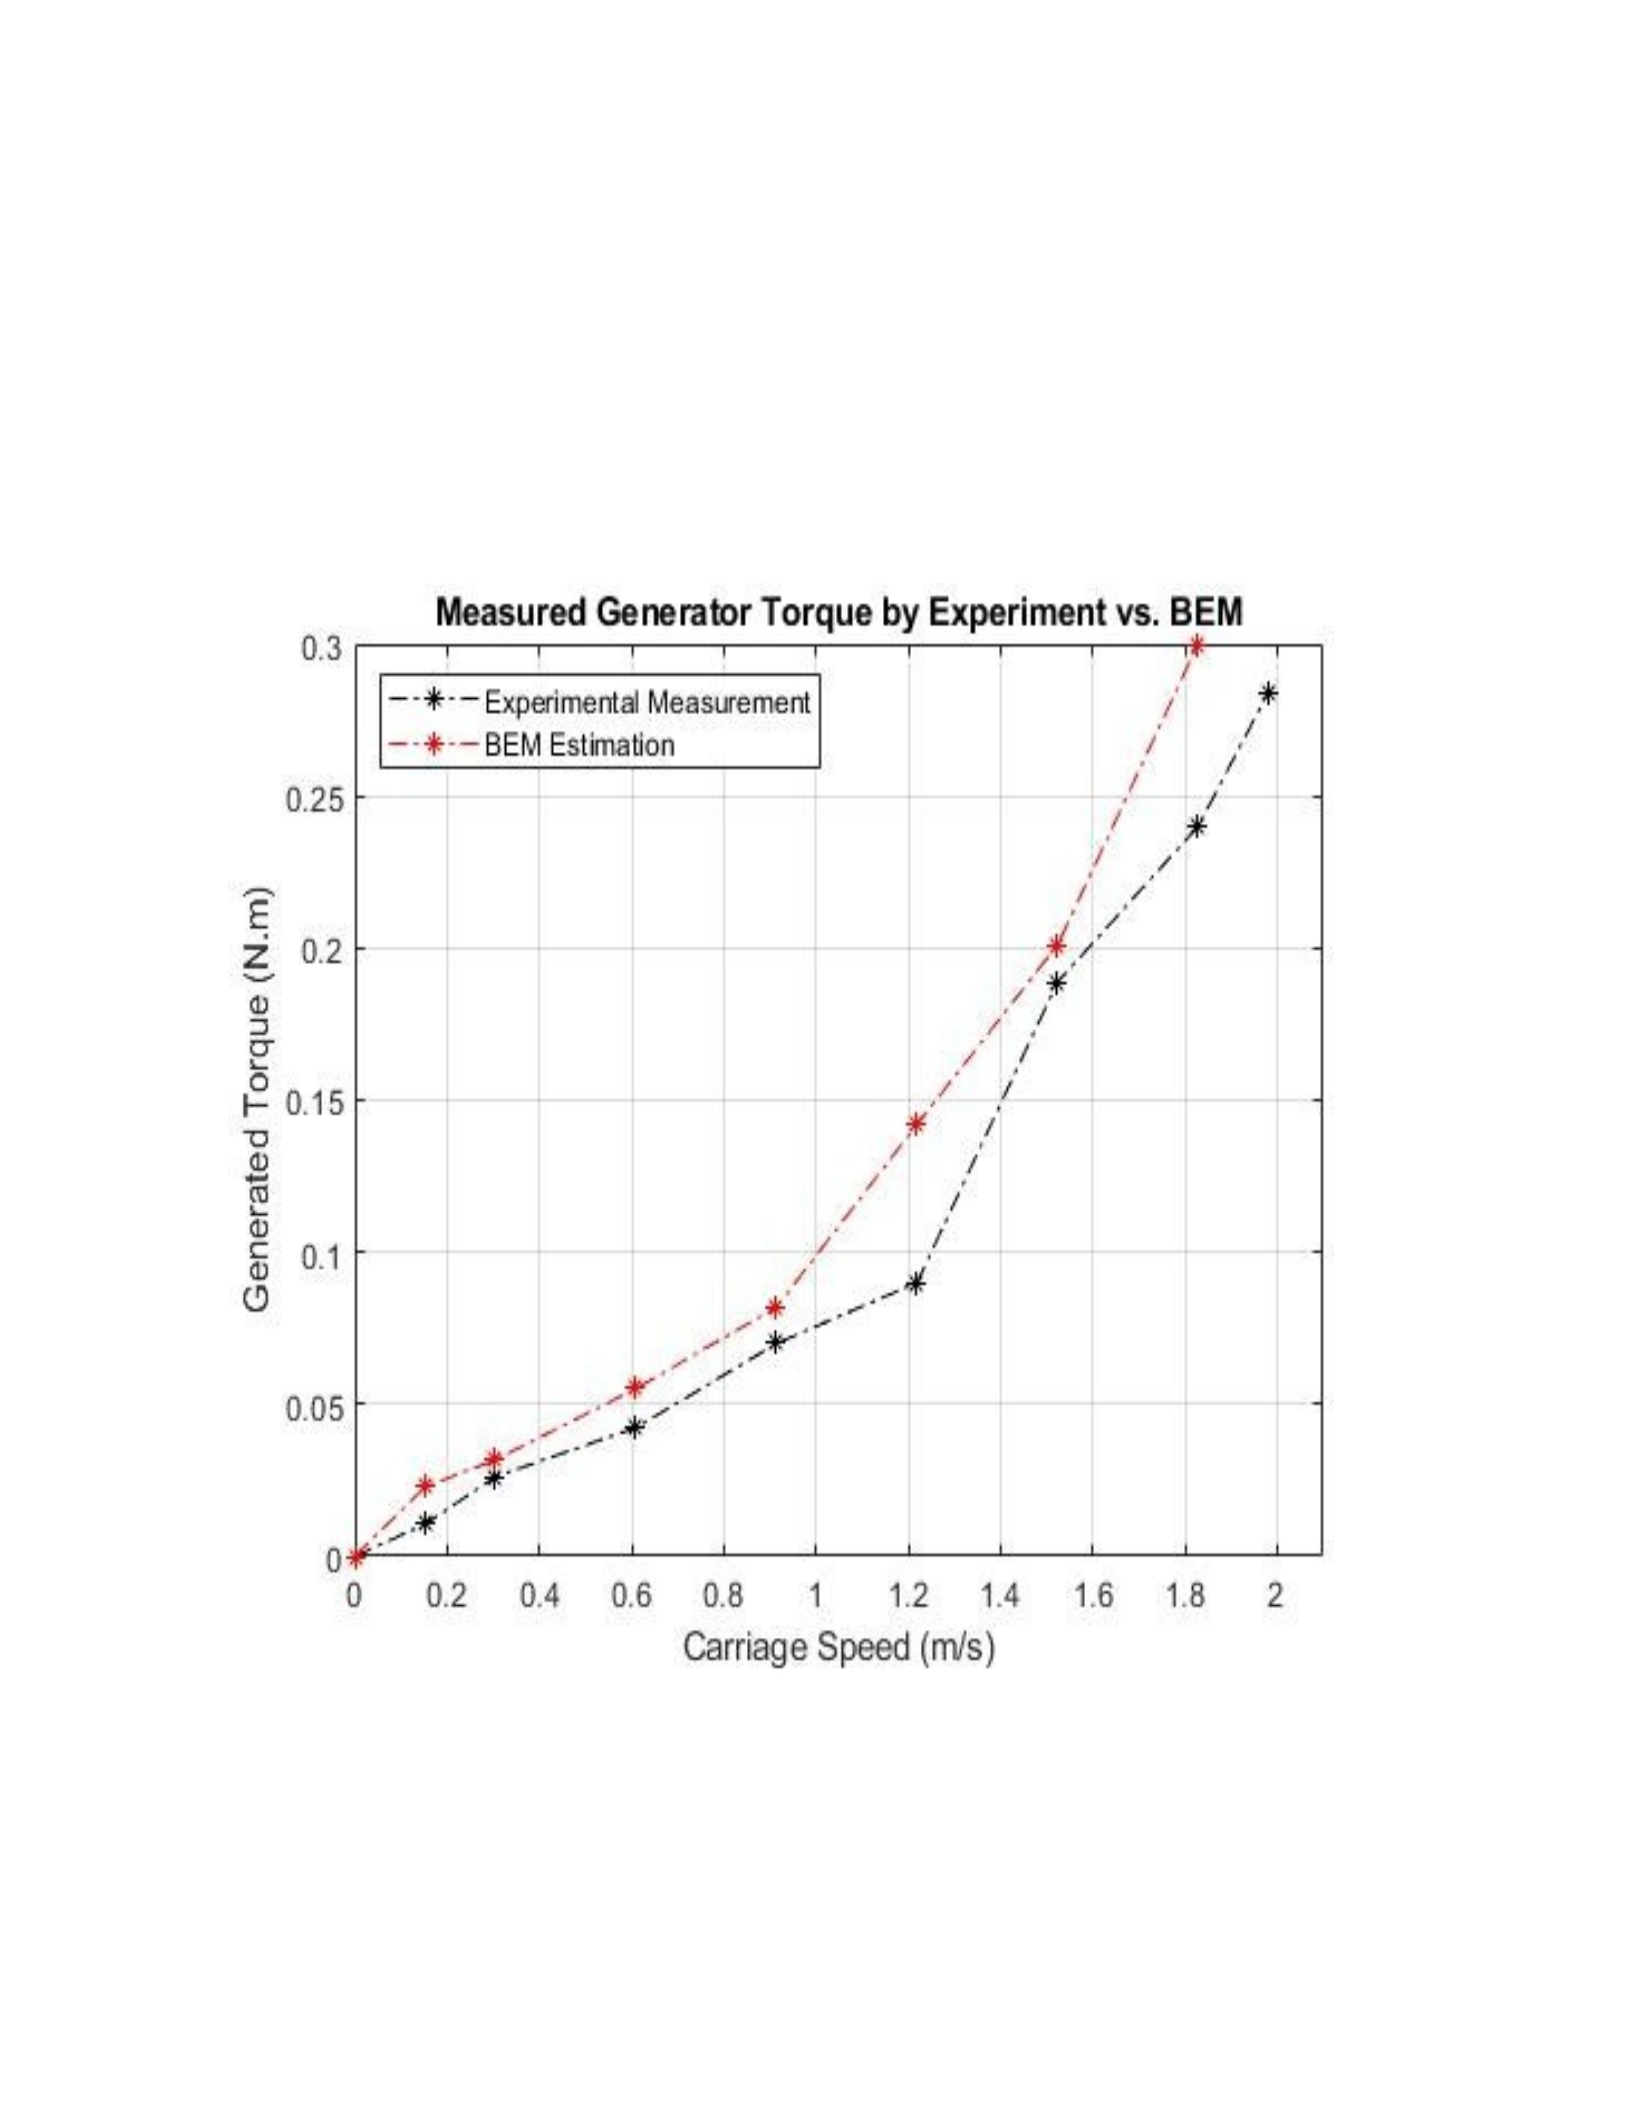
85
However, it was larger than the experimental findings until the speed of the train reached 2
m/s. This difference between experimental data and BEM simulations can be caused by a
number of factors. One possibility is that there are some measurement errors because the
experimental settings or equipment used to measure the power generated are not accurate
enough. Another hypothesis is that some of the complex aerodynamic effects that manifest in
actual OCT, especially at higher water velocities, may not be adequately represented by BEM
simulations (96,97,98)
Figure 4.15 RESULTING TORQUE MEASURED BY EXPERIMENT VS. BEM FOR
SMALL-SCALE OCT

86
Figure 4.15 shows the speed of the train on the x-axis and the resulting torque on the y-axis. The
rotational force of the turbine blades of an underwater current, known as "generated torque",
drives the turbine rotors, which ultimately generate electricity. The upward tilt trend on the graph
shows that when the train speed is increased from 0 to 2 (m/s), the resulting torque also increases
from 0 to 0.3 (Nm) in the BEM simulation and 0 to 0.28 (Nm) in the experiment. This is
expected because the amount of energy available in the moving fluid, which rises at the current
velocity, is directly proportional to the torque created. Experimental data showed that the torque
was slightly smaller than what the BEM calculation projected. This suggests that the
performance of underwater current turbines may be somewhat exaggerated in BEM simulations.
The differences are within the tolerable uncertainty range, so the difference between the
experimental data and the BEM simulation is not significant. [96,97,98] The fact that BEM
simulations and experiments show good agreement in the results is significant because it shows
that simulations accurately predict system behavior in the real world. This suggests that BEM
models can be relied upon to make predictions about system performance under different
conditions, which can be useful in optimizing the design of turbine blades or other components
of the system. Experiments and momentum of the bar element show that simulations are able to
accurately predict how the system will behave in practice. This is important because it shows that
OCT performance can be predicted in a variety of situations, and the design of the blade or other
system components can be improved. It is important to remember that there can be a wide
variety of causes of uncertainty in both computer models and actual measurements, and it is
often difficult to measure this uncertainty correctly. Many elements, such as variations in current
speed and direction, water conditions, and the intricate hydrodynamics of the rotating blades, can
have an impact on how well an underwater current turbine performs. As a result, it is normal to
observe some differences between the simulation results and the experimental data.
4.4 Comparison of the final round of BEM experiments and simulations:
Initial trials of the hydrokinetic turbine project revealed a significant complication: water
leakage from the propeller pipes. This issue raises concerns about the integrity of the
experiment and the overall functionality of the turbine for further research. To overcome this
challenge, a solution involving a magnetic coupling through the shaft was implemented.
Magnetic couplings, a mechanism that facilitates the transfer of torque between rotating shafts
without direct physical contact, were chosen for their ability to provide a watertight seal,
preventing fluid leakage. The leak problem highlights the importance of immediately
addressing unexpected challenges in research efforts. Water escaping from the propeller pipe
endangers the controlled environment required for proper experimentation, with potential
consequences extending to subsequent trials and the overall functionality of the turbine.
In response, a strategic solution involving a magnetic coupling through a shaft was designed.
This innovative approach reduces the leakage problem by introducing a separation layer between
the rotating shafts, allowing for the transfer of torque through a magnetic field. Magnetic
coupling

87
It has a dual purpose: ensuring continuous torque transfer for operational functionality and
establishing an effective barrier against fluid leakage, essential for maintaining a controlled
environment in underwater testing scenarios.
The implementation of the magnetic coupling is a transformative improvement on the
experimental setting. In addition to fixing the problem of direct leaks, it introduces technological
sophistication that is in tune with contemporary engineering practices. The non-contact nature of
magnetic couplings offers advantages over traditional mechanical couplings, minimizing friction,
reducing wear, and eliminating the need for complex sealing arrangements. This option not only
maintains the functionality of the turbine but also improves the reliability and repeatability of
experimental results.
The iterative nature of experimental research is evident in the dynamic response to the leak
problem. Identification of challenges leads to the integration of new solutions, reflecting a
commitment to continuous improvement and the pursuit of excellence in research efforts.
Magnetic couplings not only overcome direct obstacles but also demonstrate adaptability and
ingenuity in overcoming the specific challenges posed by fluid leaks.
In conclusion, encounters with leak issues during the initial trial of the hydrokinetic turbine
project encouraged a thoughtful and proactive response. The application of magnetic coupling
through the shaft demonstrates the adaptability and ingenuity inherent in experimental research.
In addition to fixing immediate challenges, these solutions introduce technological
sophistication, improving the precision and reliability of hydrokinetic testing. The iterative
process of identifying challenges, designing solutions, and refining experimental protocols
exemplifies a commitment to overcoming obstacles and advancing the field of hydrodynamics.
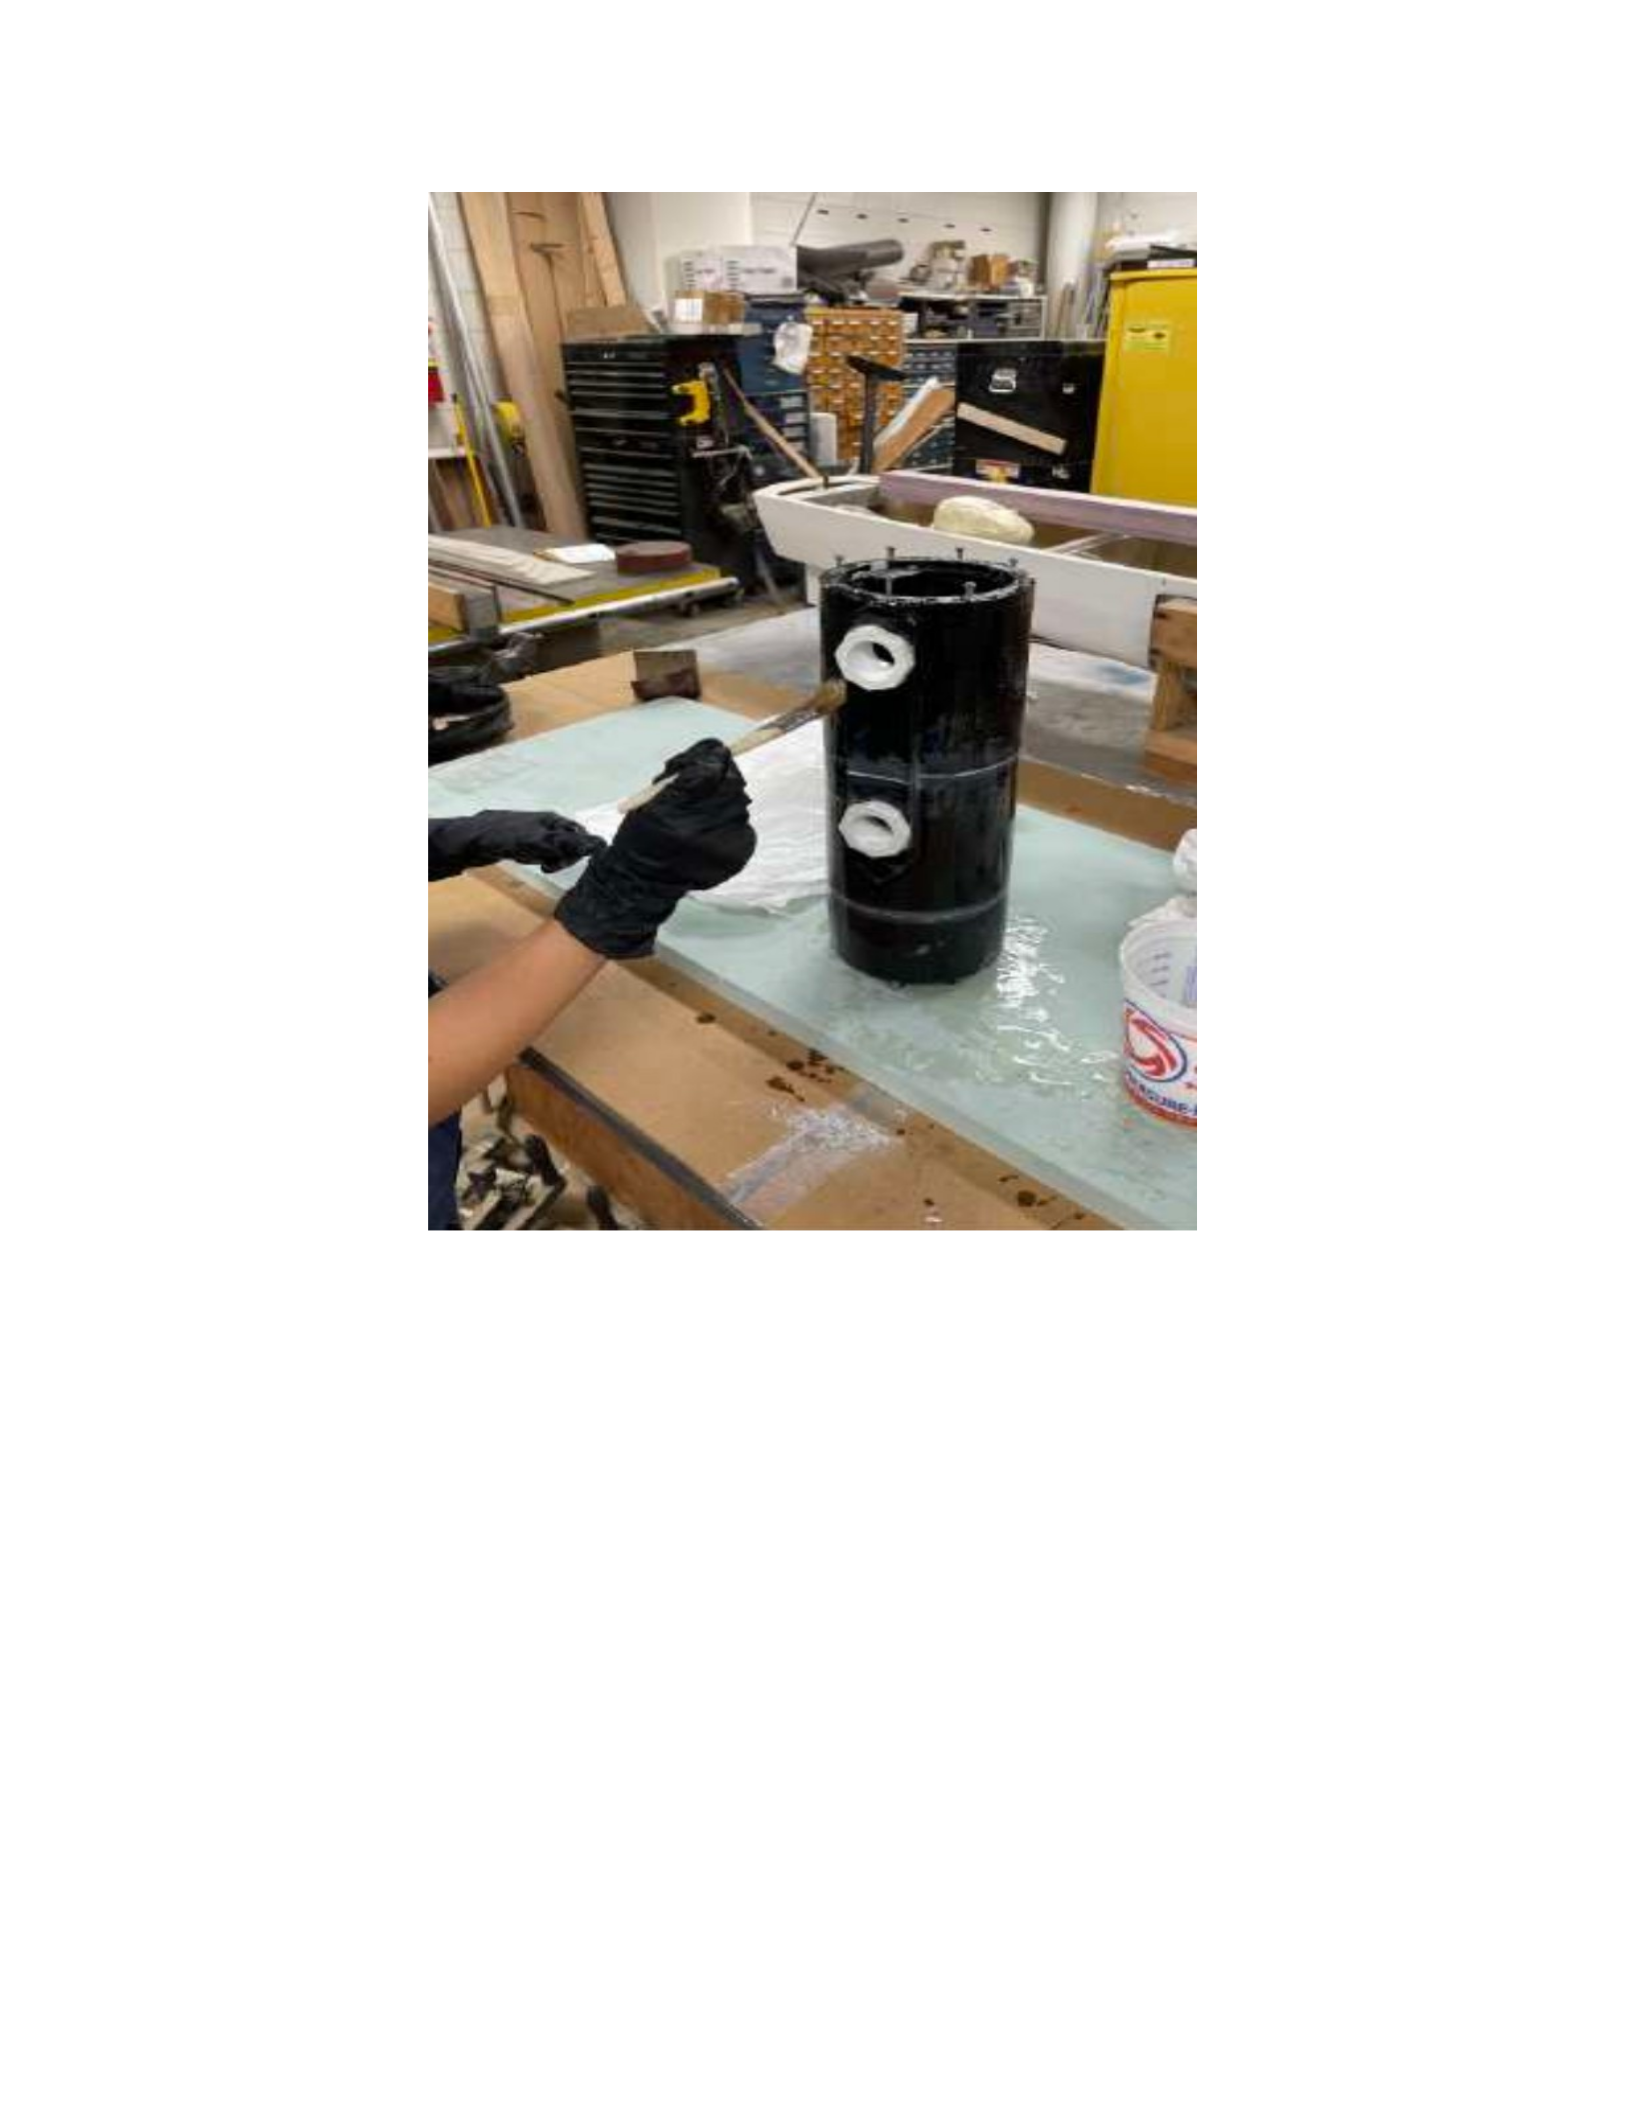
88
Figure 4.16 Revised nacelle coated with epoxy.
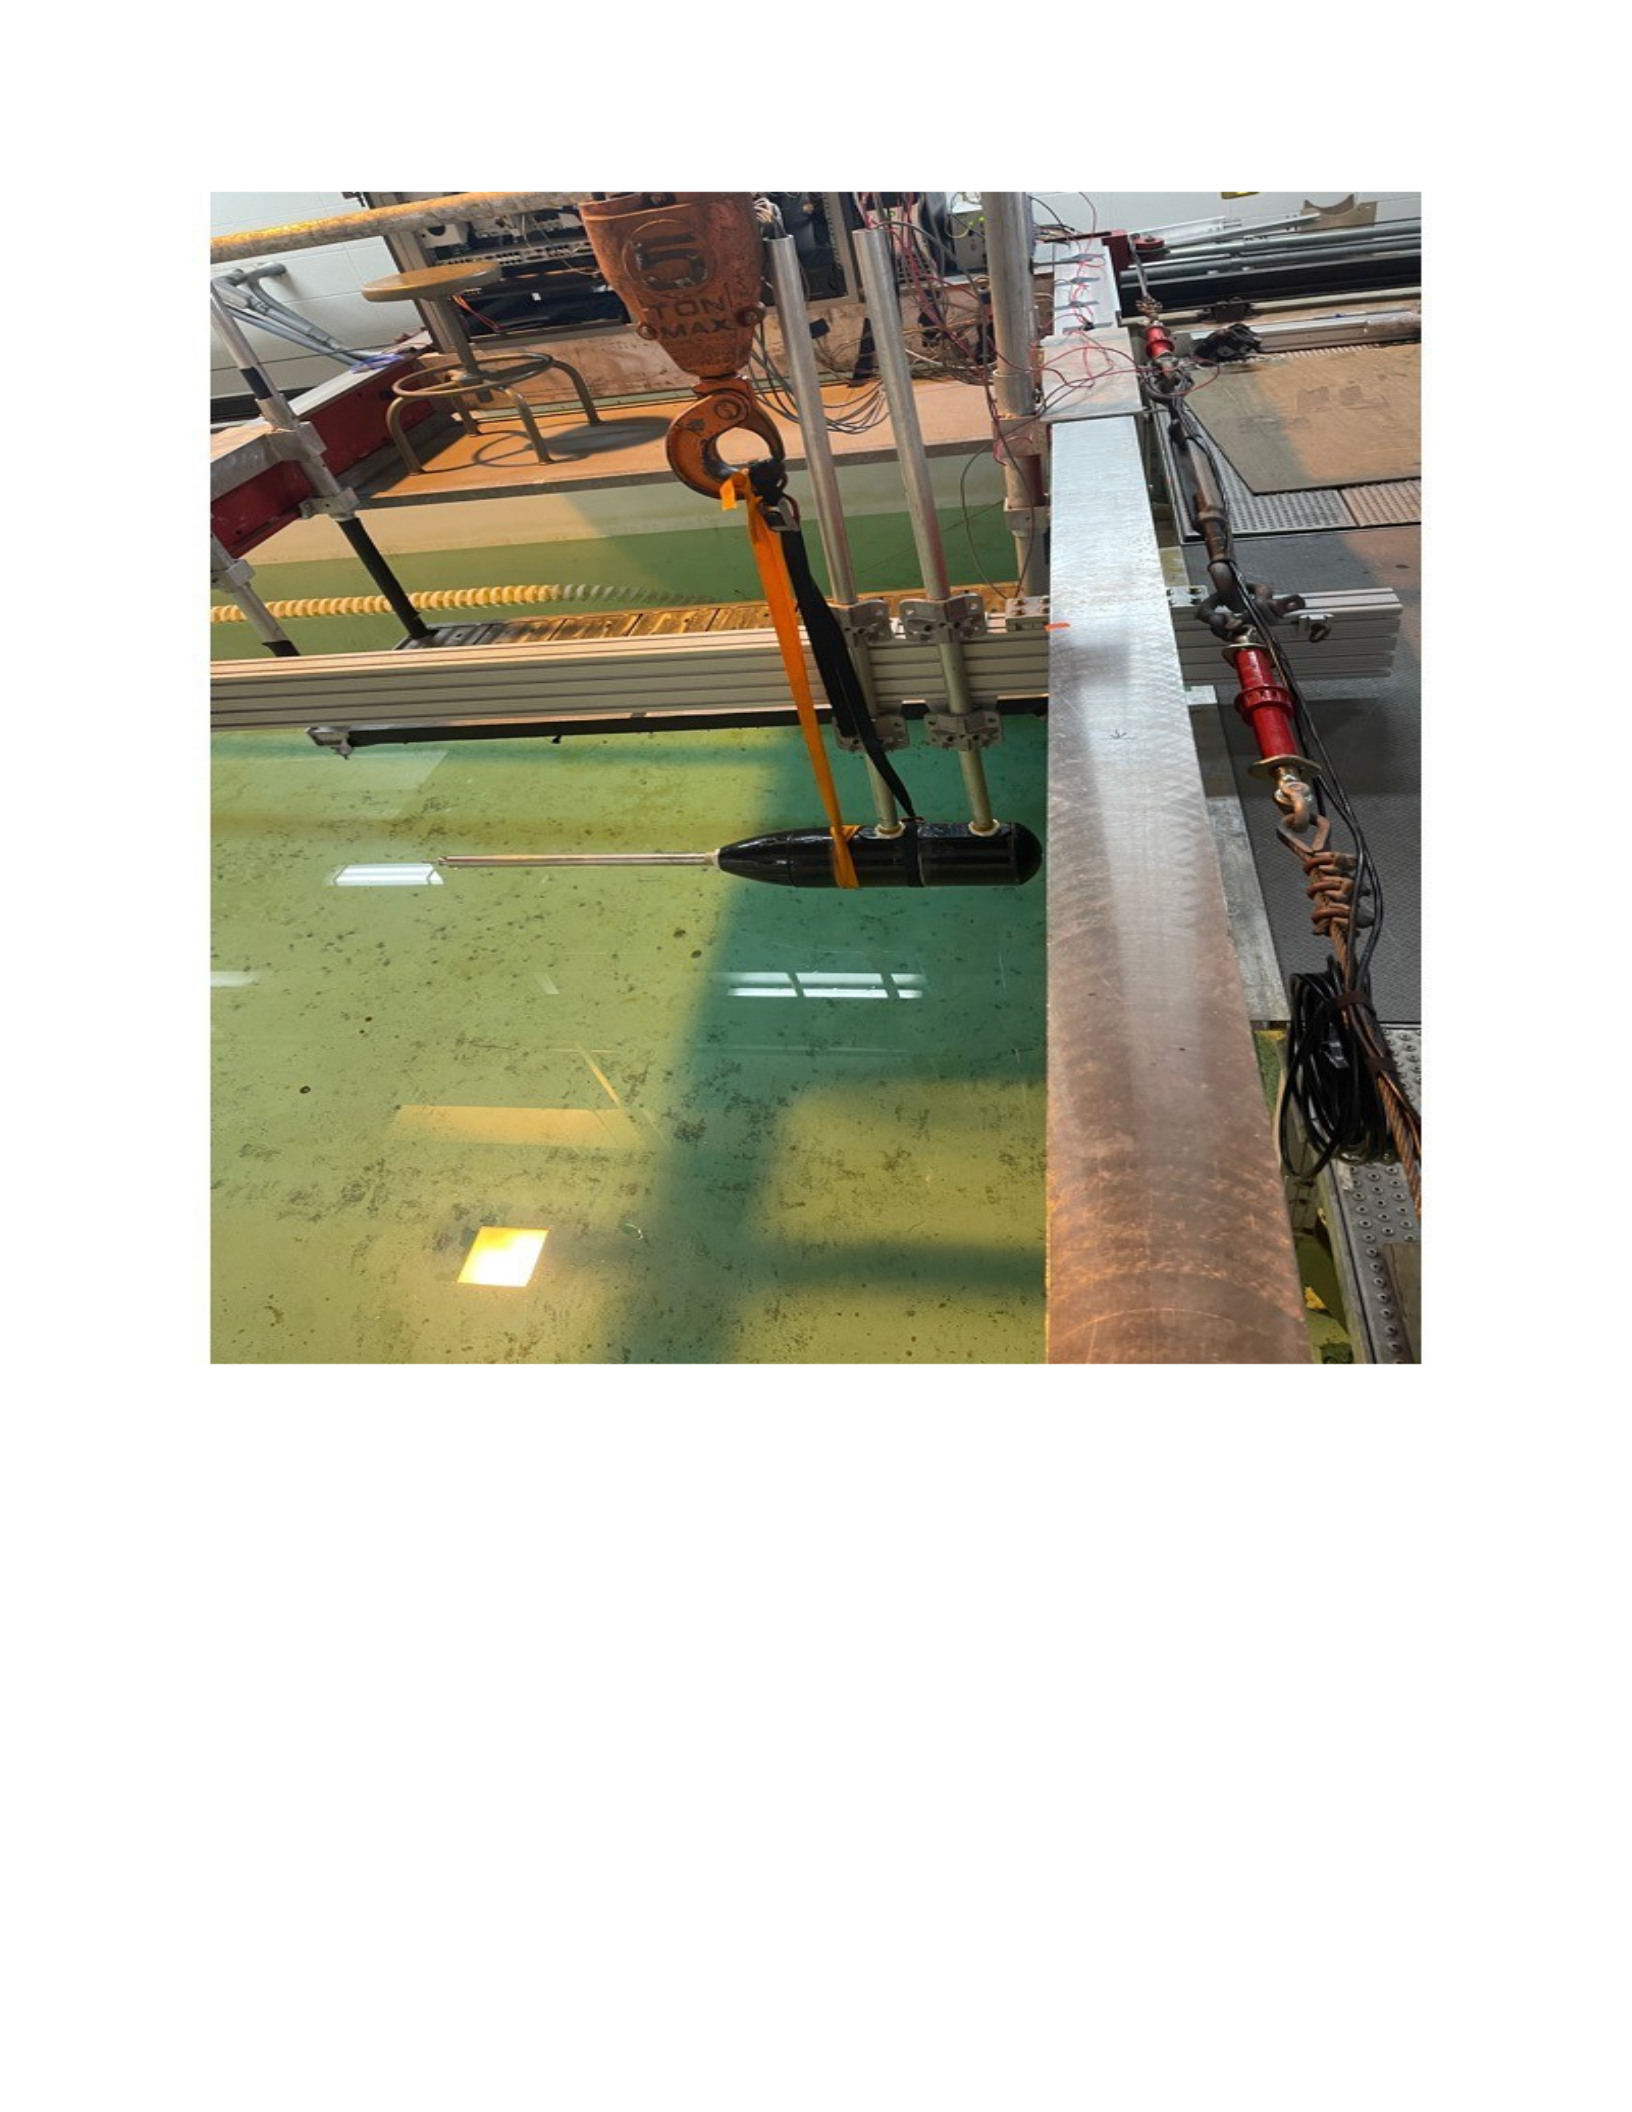
89
Figure 4.17 Revised Nacelle Coated with Epoxy and Ready for Testing.
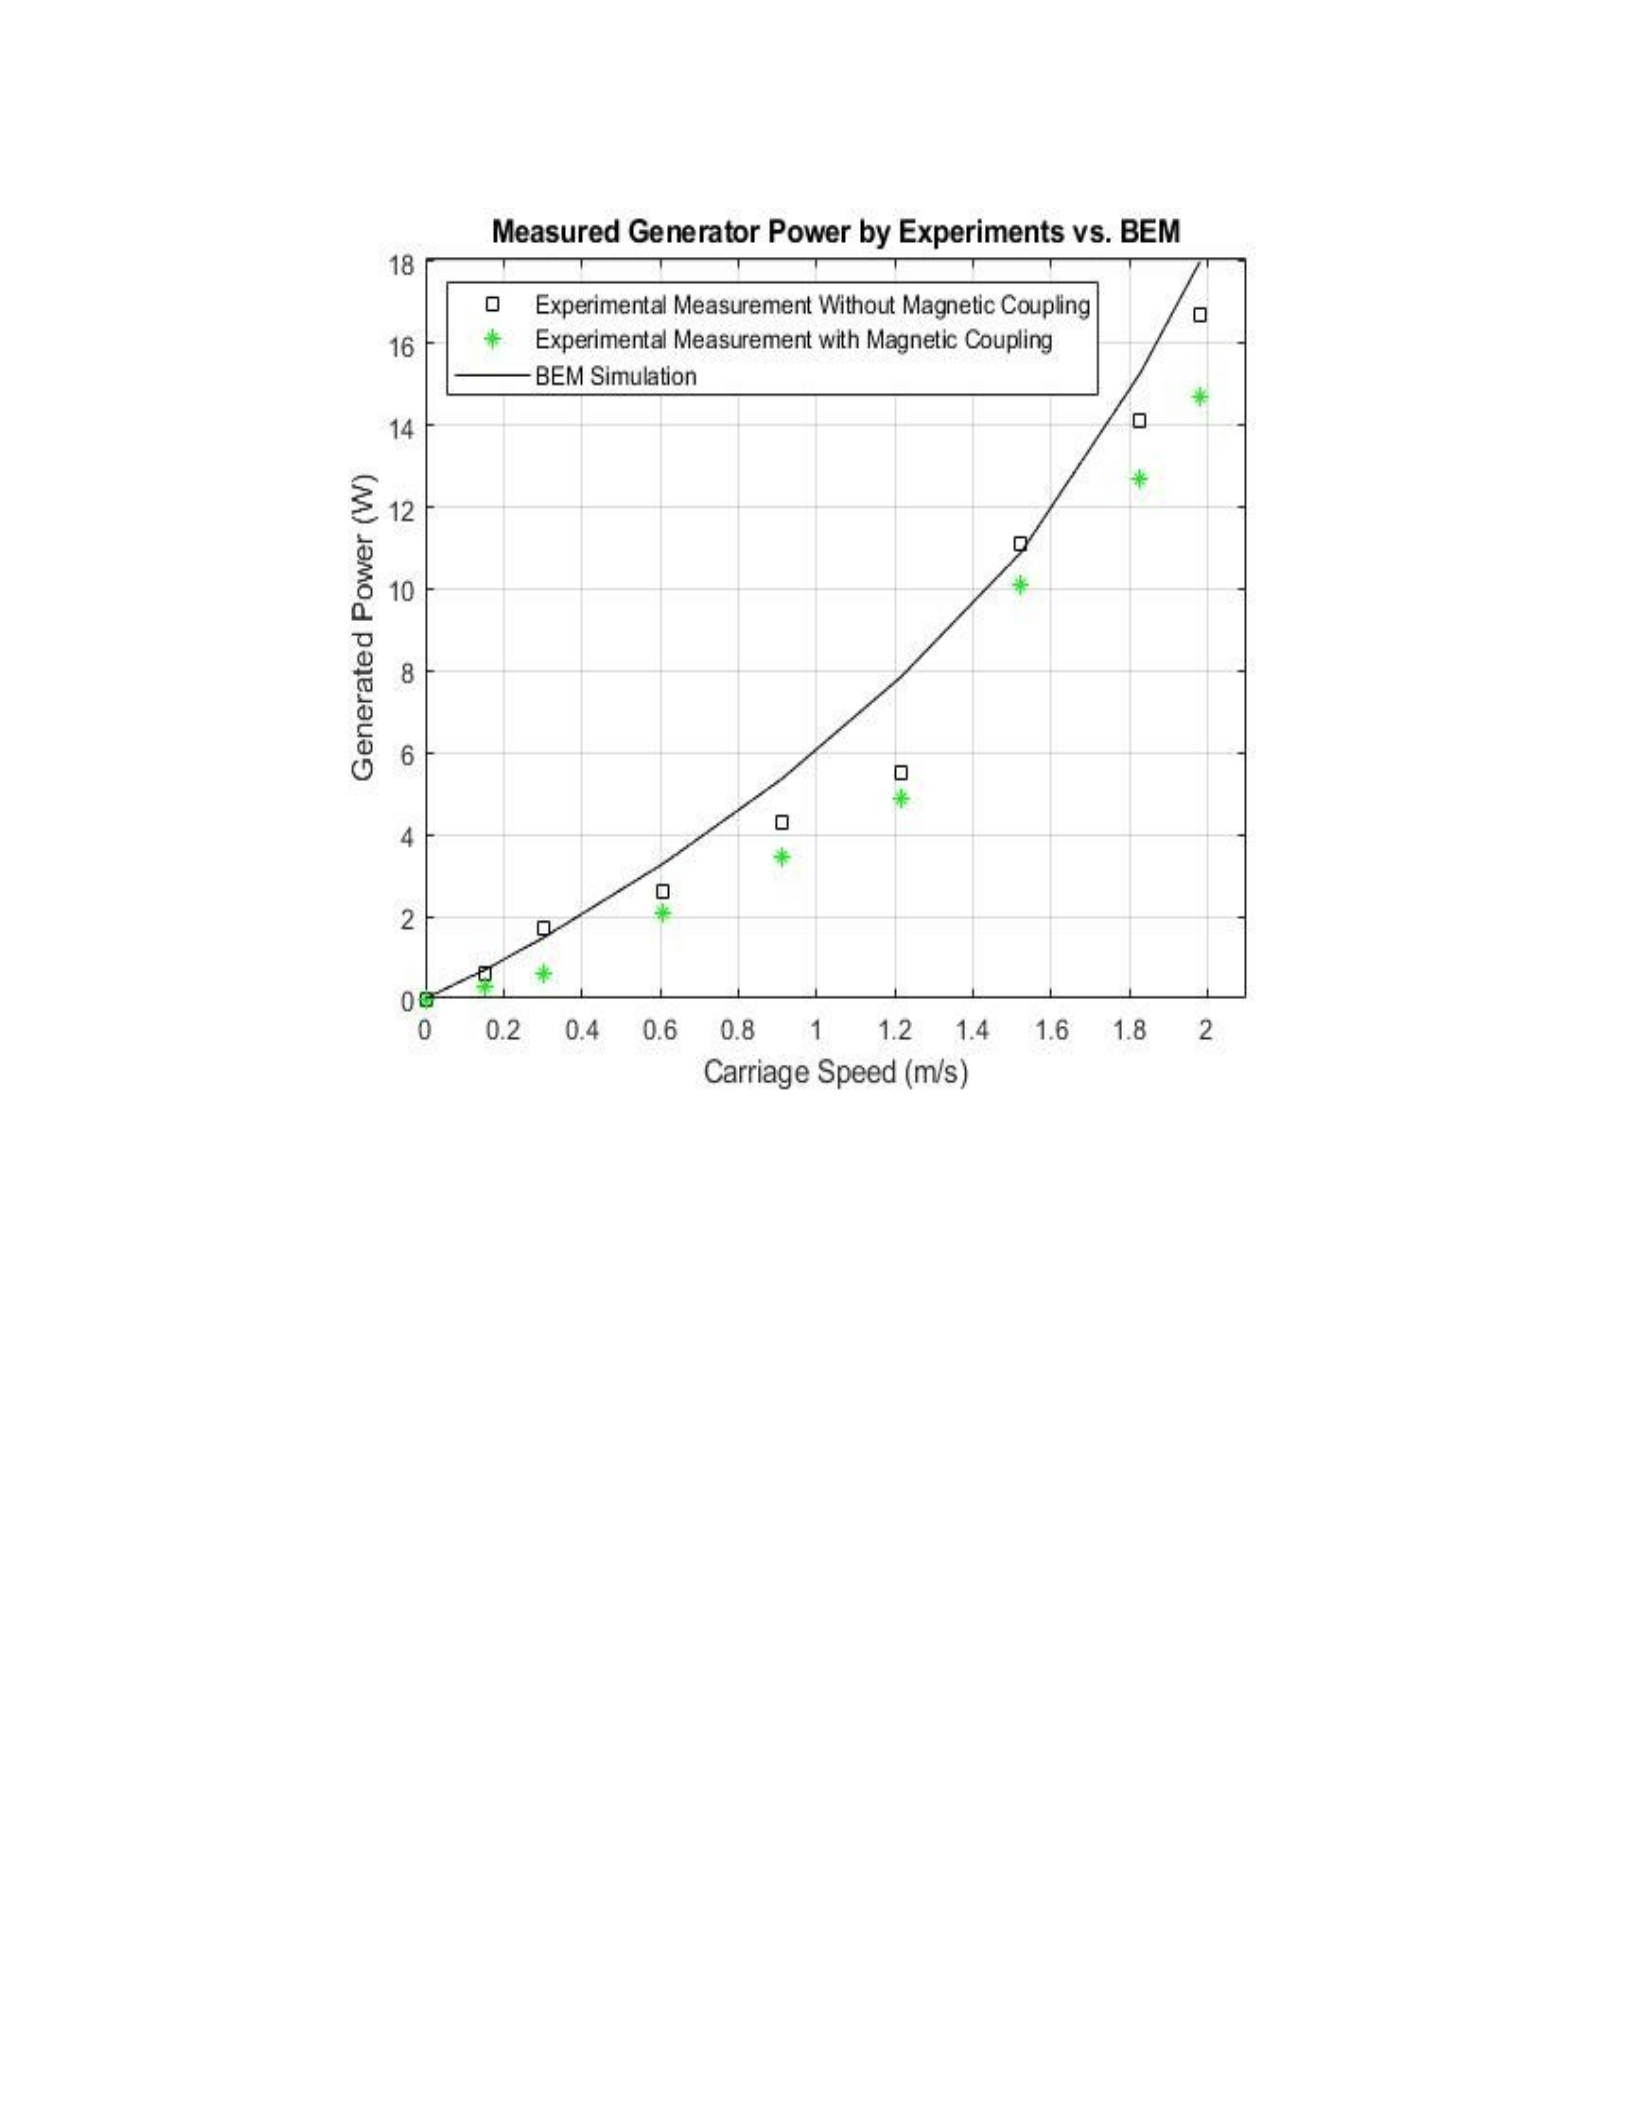
90
Figure 4.18 Measured Power Generated WITH Experiments with and without Magnetic
Coupling VS. SMALL-SCALE BEM OCT
Figure 4.18 illustrates the comparison between the power generated measured for different train
speeds from experiments with and without magnetic couplings, versus the results obtained from
Blade Element Momentum (BEM) or Small Scale Ocean Current Turbines (OCT) have yielded
interesting insights. In particular, the data reveal a commendable agreement between the results
obtained through BEM simulations and an experimental setup incorporating a magnetic clutch
for train speeds ranging between 0 and 2 m/s. The synchronization in these results underscores
the reliability and accuracy of numerical simulations, which are based on the principles of BEM,
and the practical experiments facilitated by the innovative inclusion of magnetic couplings. The
consistency between theoretical predictions and experimental observations in this speed range
signals a harmonious alignment between the predictive capabilities of BEM and the real-world
performance of hydrokinetic turbines, which further validates the efficacy of magnetic couplings
in improving experimental precision.
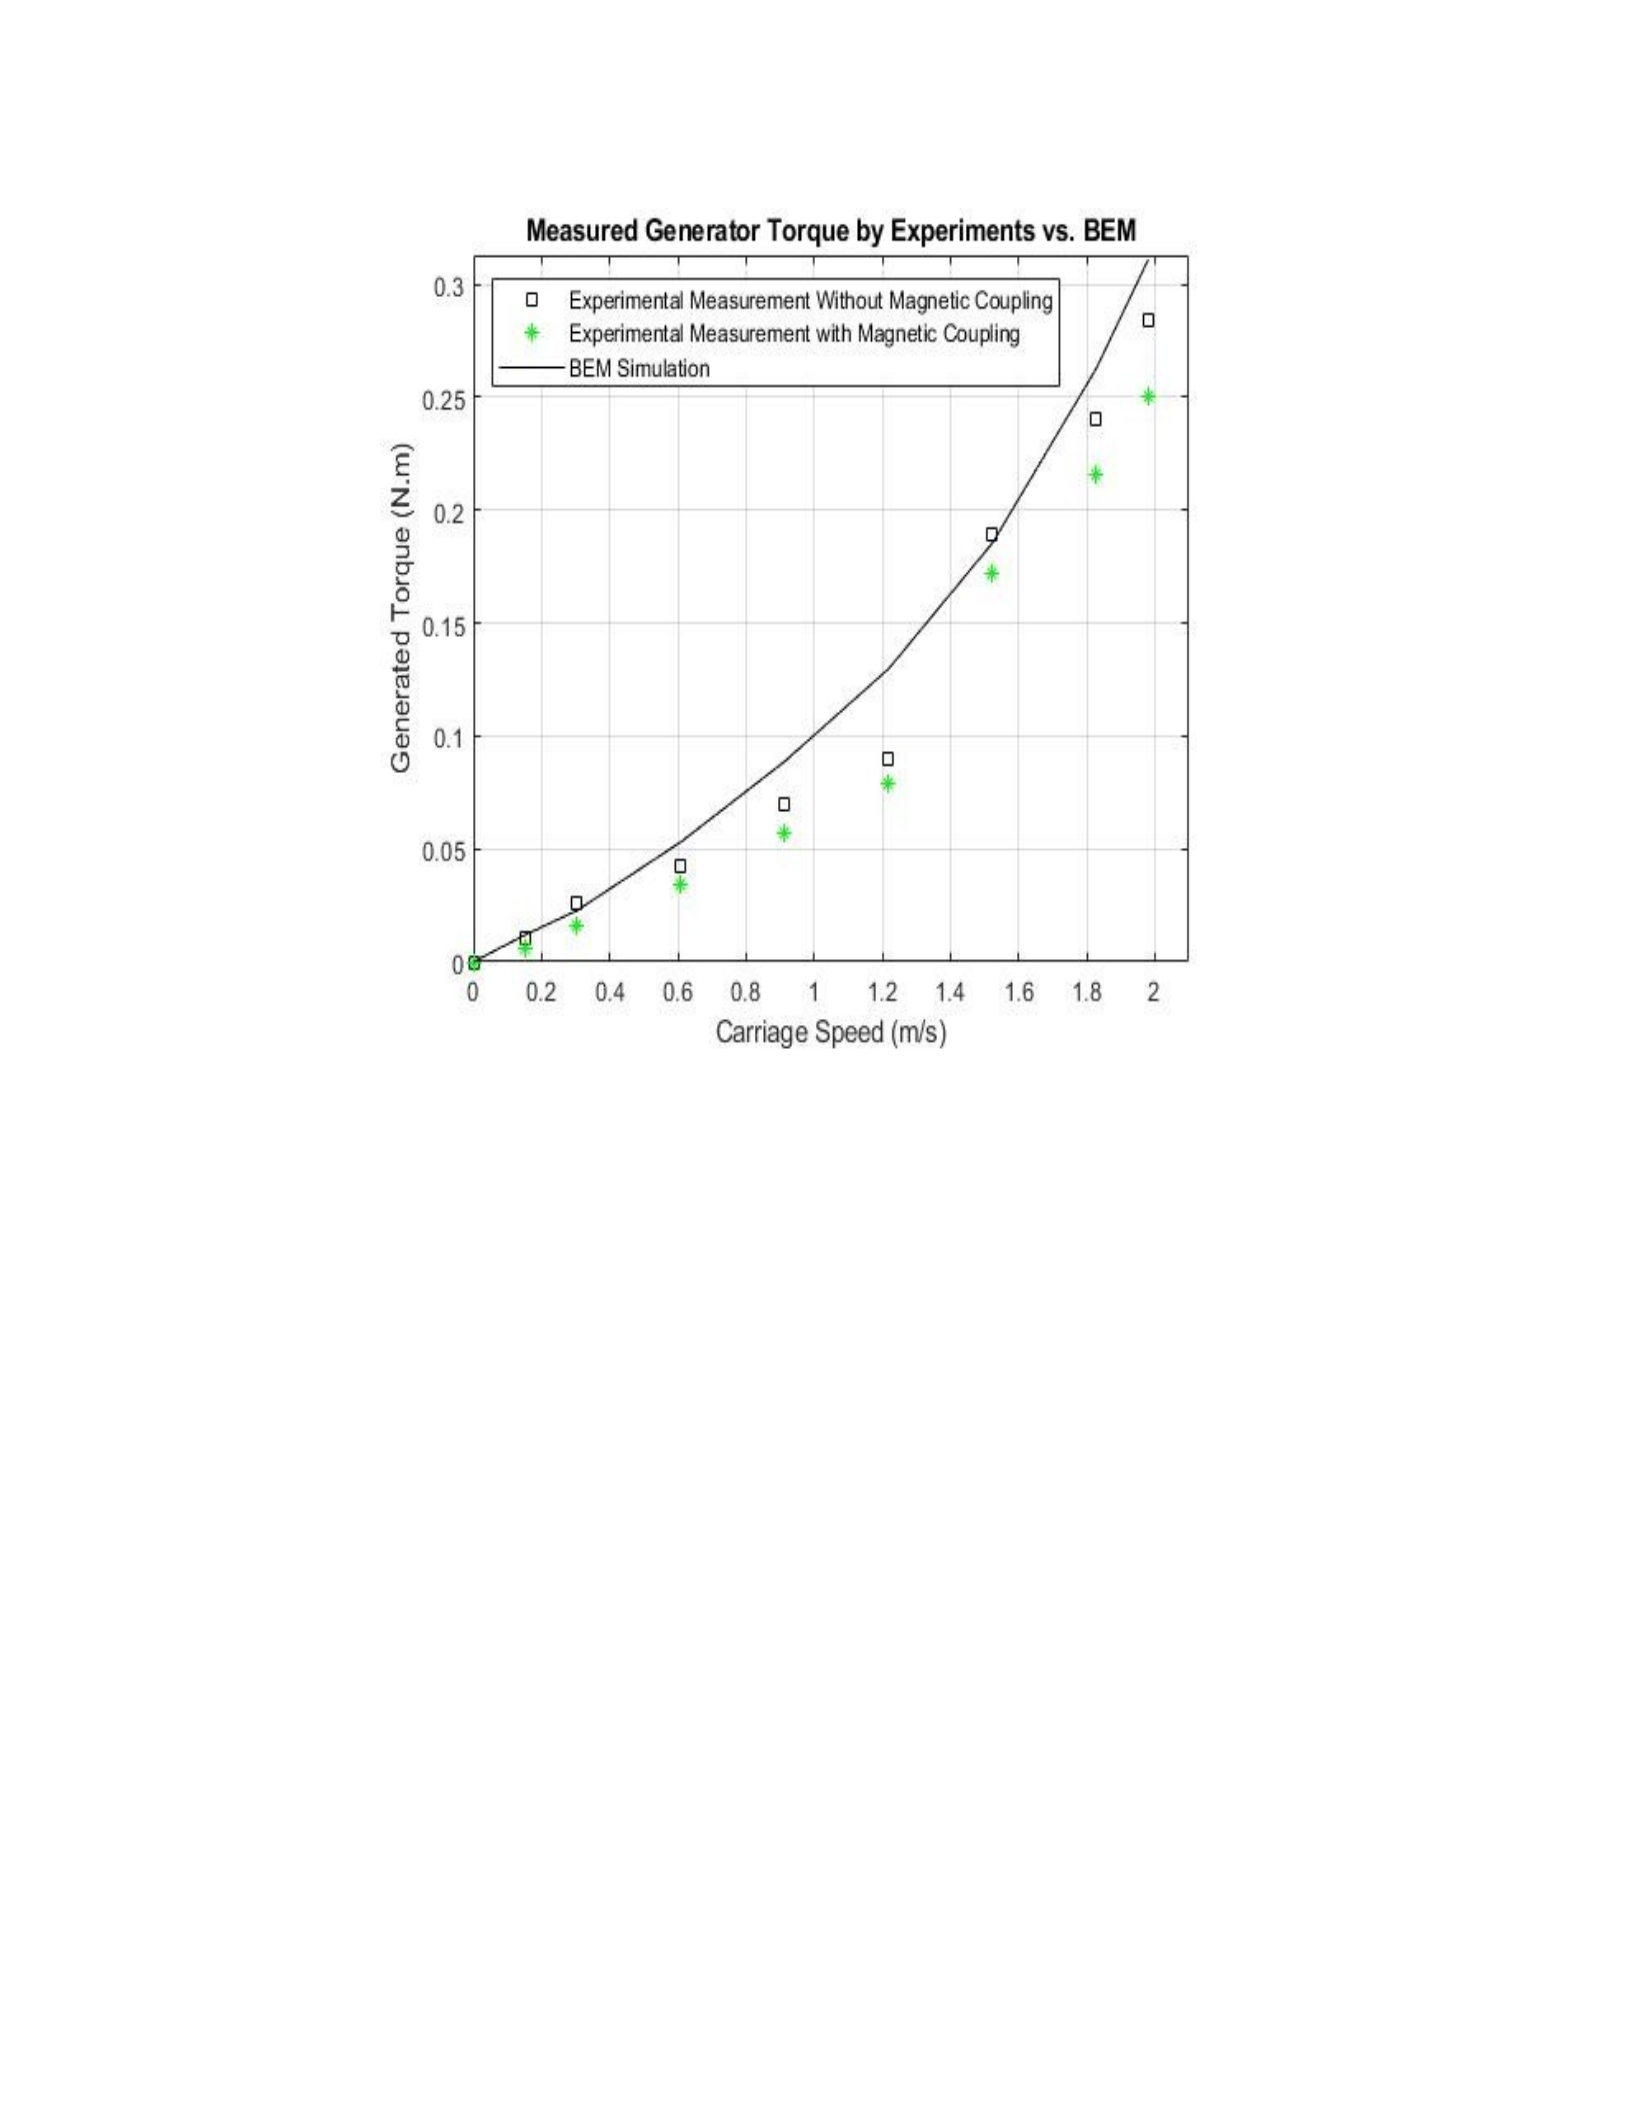
91
Figure 4.19 Measured Torque WITH Experiments with and without Magnetic Coupling VS.
SMALL-SCALE BEM OCT
A graphical representation in 4.19 of the generated torque measured versus the speed of the train,
comparing experiments conducted with or without a magnetic clutch, in addition to the results
predicted by the Blade Element Momentum (BEM) or Small Scale Ocean Current Turbine
(OCT), reveals an interesting trend. Significantly, the results of experiments incorporating
magnetic couplings consistently showed the smallest torque values for each measured speed,
highlighting the efficacy of magnetic couplings in minimizing torque generation. This
observation applies when compared to BEM simulations and experiments conducted without
magnetic couplings. The experimental conditions in these three scenarios demonstrate an
important and consistent agreement on torque values, emphasizing the reliability and
reproducibility of experimental data. This convergence in torque results reinforces the role of
magnetic coupling as an influential factor in regulating torque at various train speeds,
contributing to a better understanding of the performance characteristics of hydrokinetic turbines.

92
Chapter 5: CFD Simulation Using Ansys-Fluent
ANSYS Fluent is an advanced computational fluid dynamics (CFD) software developed by
ANSYS Inc., a leading provider of engineering simulation solutions. Fluent is specifically
designed to simulate fluid flow, heat transfer, and chemical reactions in a variety of applications
in a variety of industries. As part of the ANSYS family, Fluent offers advanced capabilities for
fluid dynamics analysis, allowing engineers and researchers to gain valuable insights into
complex flow phenomena (102-105).
Fluent uses numerical methods to solve equations that govern fluid flow, such as the Navier-
Stokes equation, which describes the motion of fluids. It uses a finite volume method, discrete
the computational domain into small control volumes in which the governing equations are
resolved repeatedly. This allows the simulation of a wide variety of fluid flow scenarios,
including laminar and turbulent flows, compressible and incompressible flows, and multiphase
flows (106-113)
One of Fluent's strengths lies in its versatility, accommodating simulations for a wide spectrum
of engineering problems. Whether analyzing aircraft aerodynamics, optimizing heat exchanger
performance, or studying fluid behavior in hydraulic systems, Fluent provides a powerful
platform for accurate and detailed simulations (114-118).
The software incorporates a user-friendly interface that facilitates simulation settings, allowing
users to determine the geometry, boundary conditions, and properties of the material.
Additionally, Fluent offers a variety of models and troubleshooters, allowing users to tailor
simulations to specific engineering challenges. It supports parallel processing, leveraging high-
performance computing resources to accelerate complex simulations.
In the context of fluid dynamics, ANSYS Fluent excels at simulating turbulent flow, a
common phenomenon in many engineering applications. It uses advanced turbulence models,
including the Reynolds-Averaged Navier-Stokes (RANS) and Large Eddy Simulation (LES)
models, to accurately capture the intricacies of turbulence (119-123). This ability is invaluable in
predicting heat transfer, pressure drop, and other important parameters in turbulent flow
scenarios.
In addition, Fluent integrates seamlessly with other ANSYS products, providing a
comprehensive simulation environment. For example, it can be combined with structural analysis
software to simulate fluid-structure interactions, improving understanding of how fluid forces
affect structural components (124-126).
The widespread adoption of ANSYS Fluent among academics and industry is proving its
reliability and effectiveness. Engineers and researchers rely on Fluent to optimize designs,
troubleshoot performance issues, and gain insights into fluid behavior under a variety of
conditions. Its applications include industries such as aerospace, automotive, energy, and
biomedical engineering.
In summary, ANSYS Fluent is a leading CFD software known for its versatility, accuracy and
powerful simulation capabilities. As part of the ANSYS family, Fluent plays a critical role in
advancing engineering simulation, enabling professionals to tackle complex fluid dynamics
challenges with confidence and precision.
The literature around hydrokinetic energy extraction underscores the importance of
understanding the complex interactions of fluid structures in turbine operations (127-131).
Numerical simulations, especially those using CFD techniques, have become an indispensable
tool in uncovering the complexity of hydrokinetic systems (131-134). Blade Element Momentum

93
Theory, a widely adopted approach, offers theoretical insights into turbine performance by
dividing turbine blades into smaller elements and applying aerodynamic principles. This theory
serves as a benchmark for comparing and validating the accuracy of numerical simulations and
practical experiments (135-140).
Renewable energy sources have attracted significant attention in recent years as people look for
sustainable alternatives to traditional power generation methods. Among them, the extraction of
hydrokinetic energy from ocean currents presents a promising avenue to utilize clean and
sustainable power. In an effort to optimize the performance of hydrokinetic turbines,
computational fluid dynamics (CFD) has emerged as a valuable tool for simulating fluid flow
around these complex structures. The study investigates the use of ANSYS Fluent, a state-of-the-
art CFD software, to simulate the performance of hydrokinetic turbines under a wide range of
current speeds. The investigation covered a range of 0 to 2 m/s, taking into account the
constraints imposed by the towing tanks at the University of New Orleans (UNO), where train
speeds were limited. The angular speed of the turbine remains constant at 500 rpm, an important
parameter for consistent comparison. The simulation results, especially the torque and power
generated, are carefully compared with those derived from the theoretical simulation of the Blade
Element Momentum (BEM) and practical experiments carried out both with and without the
magnetic clutch.
ANSYS Fluent, the leading CFD software, has been increasingly used in the renewable
energy sector to model and optimize various systems. Its ability to simulate transient flow,
important for capturing the dynamic behavior of rotating turbines, makes it particularly suitable
for hydrokinetic applications. The selection of the k-omega Viscous Shear-Stress Transport
(SST) turbulence model in Fluent underscores the importance of accurately capturing the
turbulent flow phenomenon in hydrokinetic turbine simulations. The existing literature
emphasizes the need for sophisticated modeling approaches to account for turbulence effects and
boundary layer phenomena in turbulent flow scenarios, essential for predicting accurate
performance metrics such as torque and power (141-146).
Conventional k-omega models are precisely designed to simulate flow within a sub-viscous
layer, capturing dynamics close to the surface. In contrast, the k-epsilon model excels at
predicting flow patterns that are slightly removed from the wall. In addition, the standard k-
omega model showed increased applicability in scenarios involving low Reynolds numbers,
demonstrating a highly nonlinearistic nature. However, it is often characterized by sensitivity to
initial guess values, leading to increased complexity in achieving convergence during simulation
(147-149).
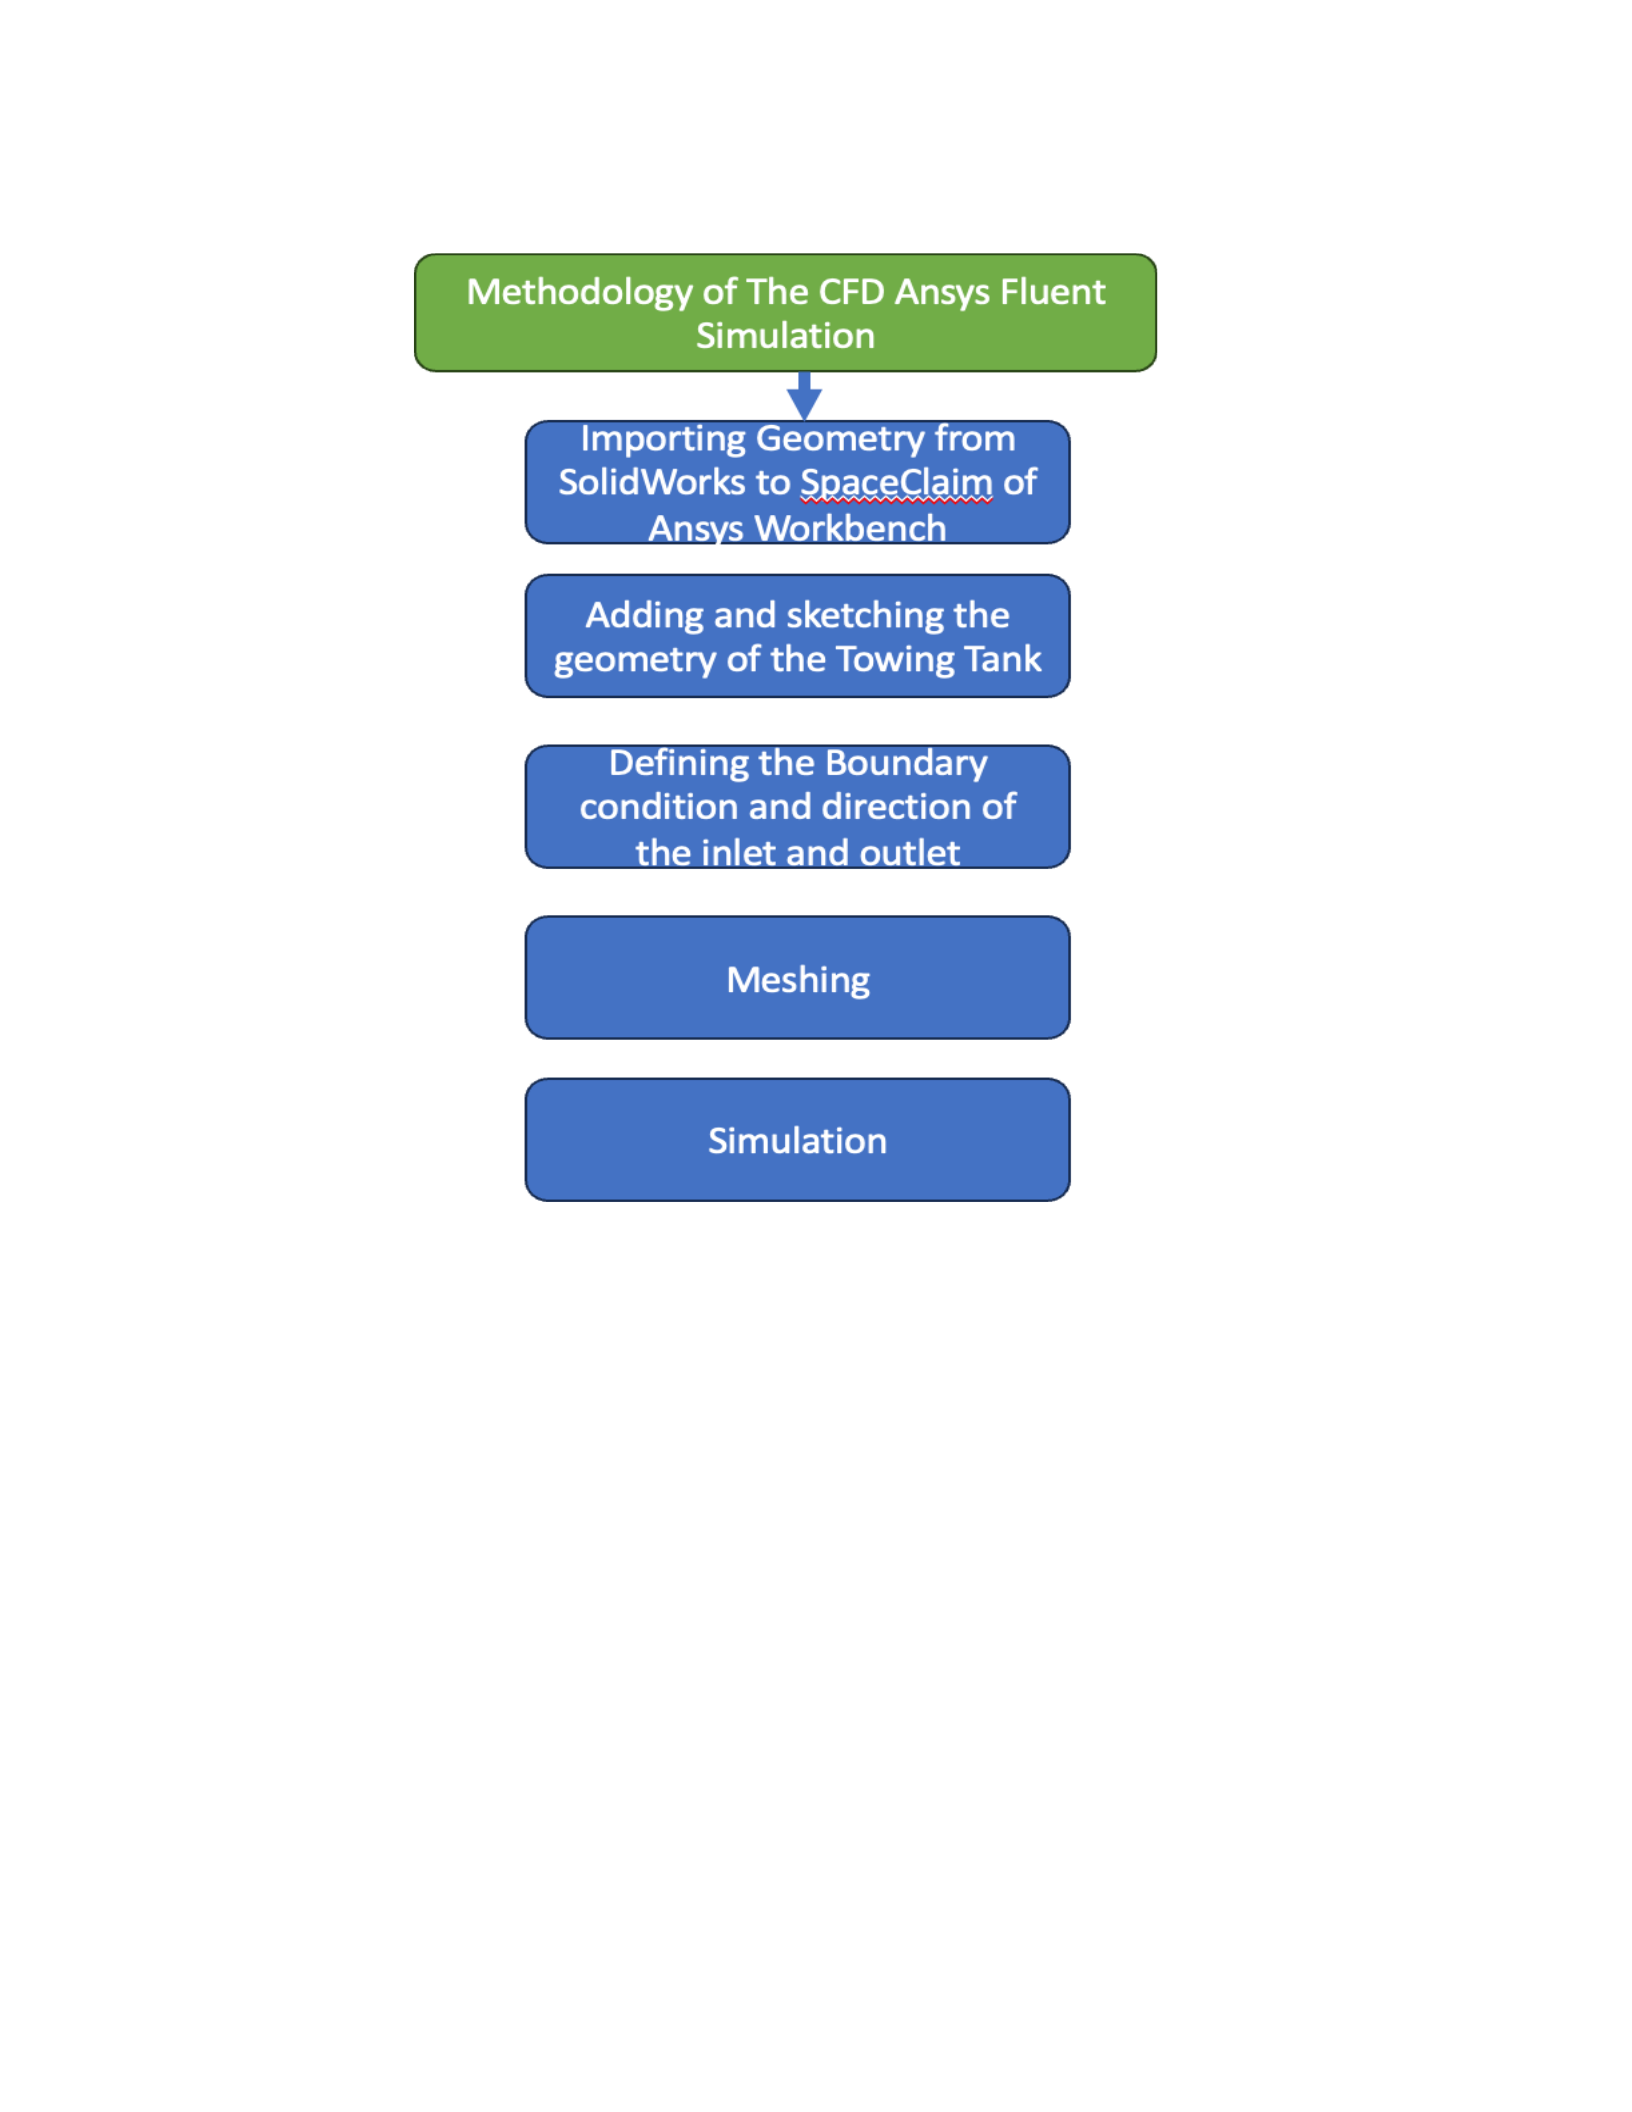
94
Figure 5.1 CFD Methodology
Figure 5.1 shows how the CFD simulation is run based on a model generated by Solidworks.
Boundary conditions in ANSYS are the basic components that determine the simulation
behavior on its external boundaries. These conditions determine how the simulation system
interacts with its environment, which affects the results of the analysis. In the context of fluid
dynamics simulation, accurate representation of physical boundaries is essential. ANSYS
provides a comprehensive set of boundary conditions to capture a wide variety of real-world
scenarios (150-154). Inlet conditions determine the characteristics of the fluid entering the
domain, determining the velocity, pressure, or temperature profile. The outlet regulates the flow
behavior as it exits the system, ensuring a smooth transition (155.156). Symmetrical walls and
conditions define interactions with solid surfaces or mirror planes, important for simulating slip-
free conditions and reducing computational demands through symmetry (157-159). In addition,
periodic boundary conditions facilitate the simulation of repetitive structures or sections,
encouraging computational efficiency. ANSYS also accommodates special conditions such as
mass flow, heat flux and special expressions, enabling
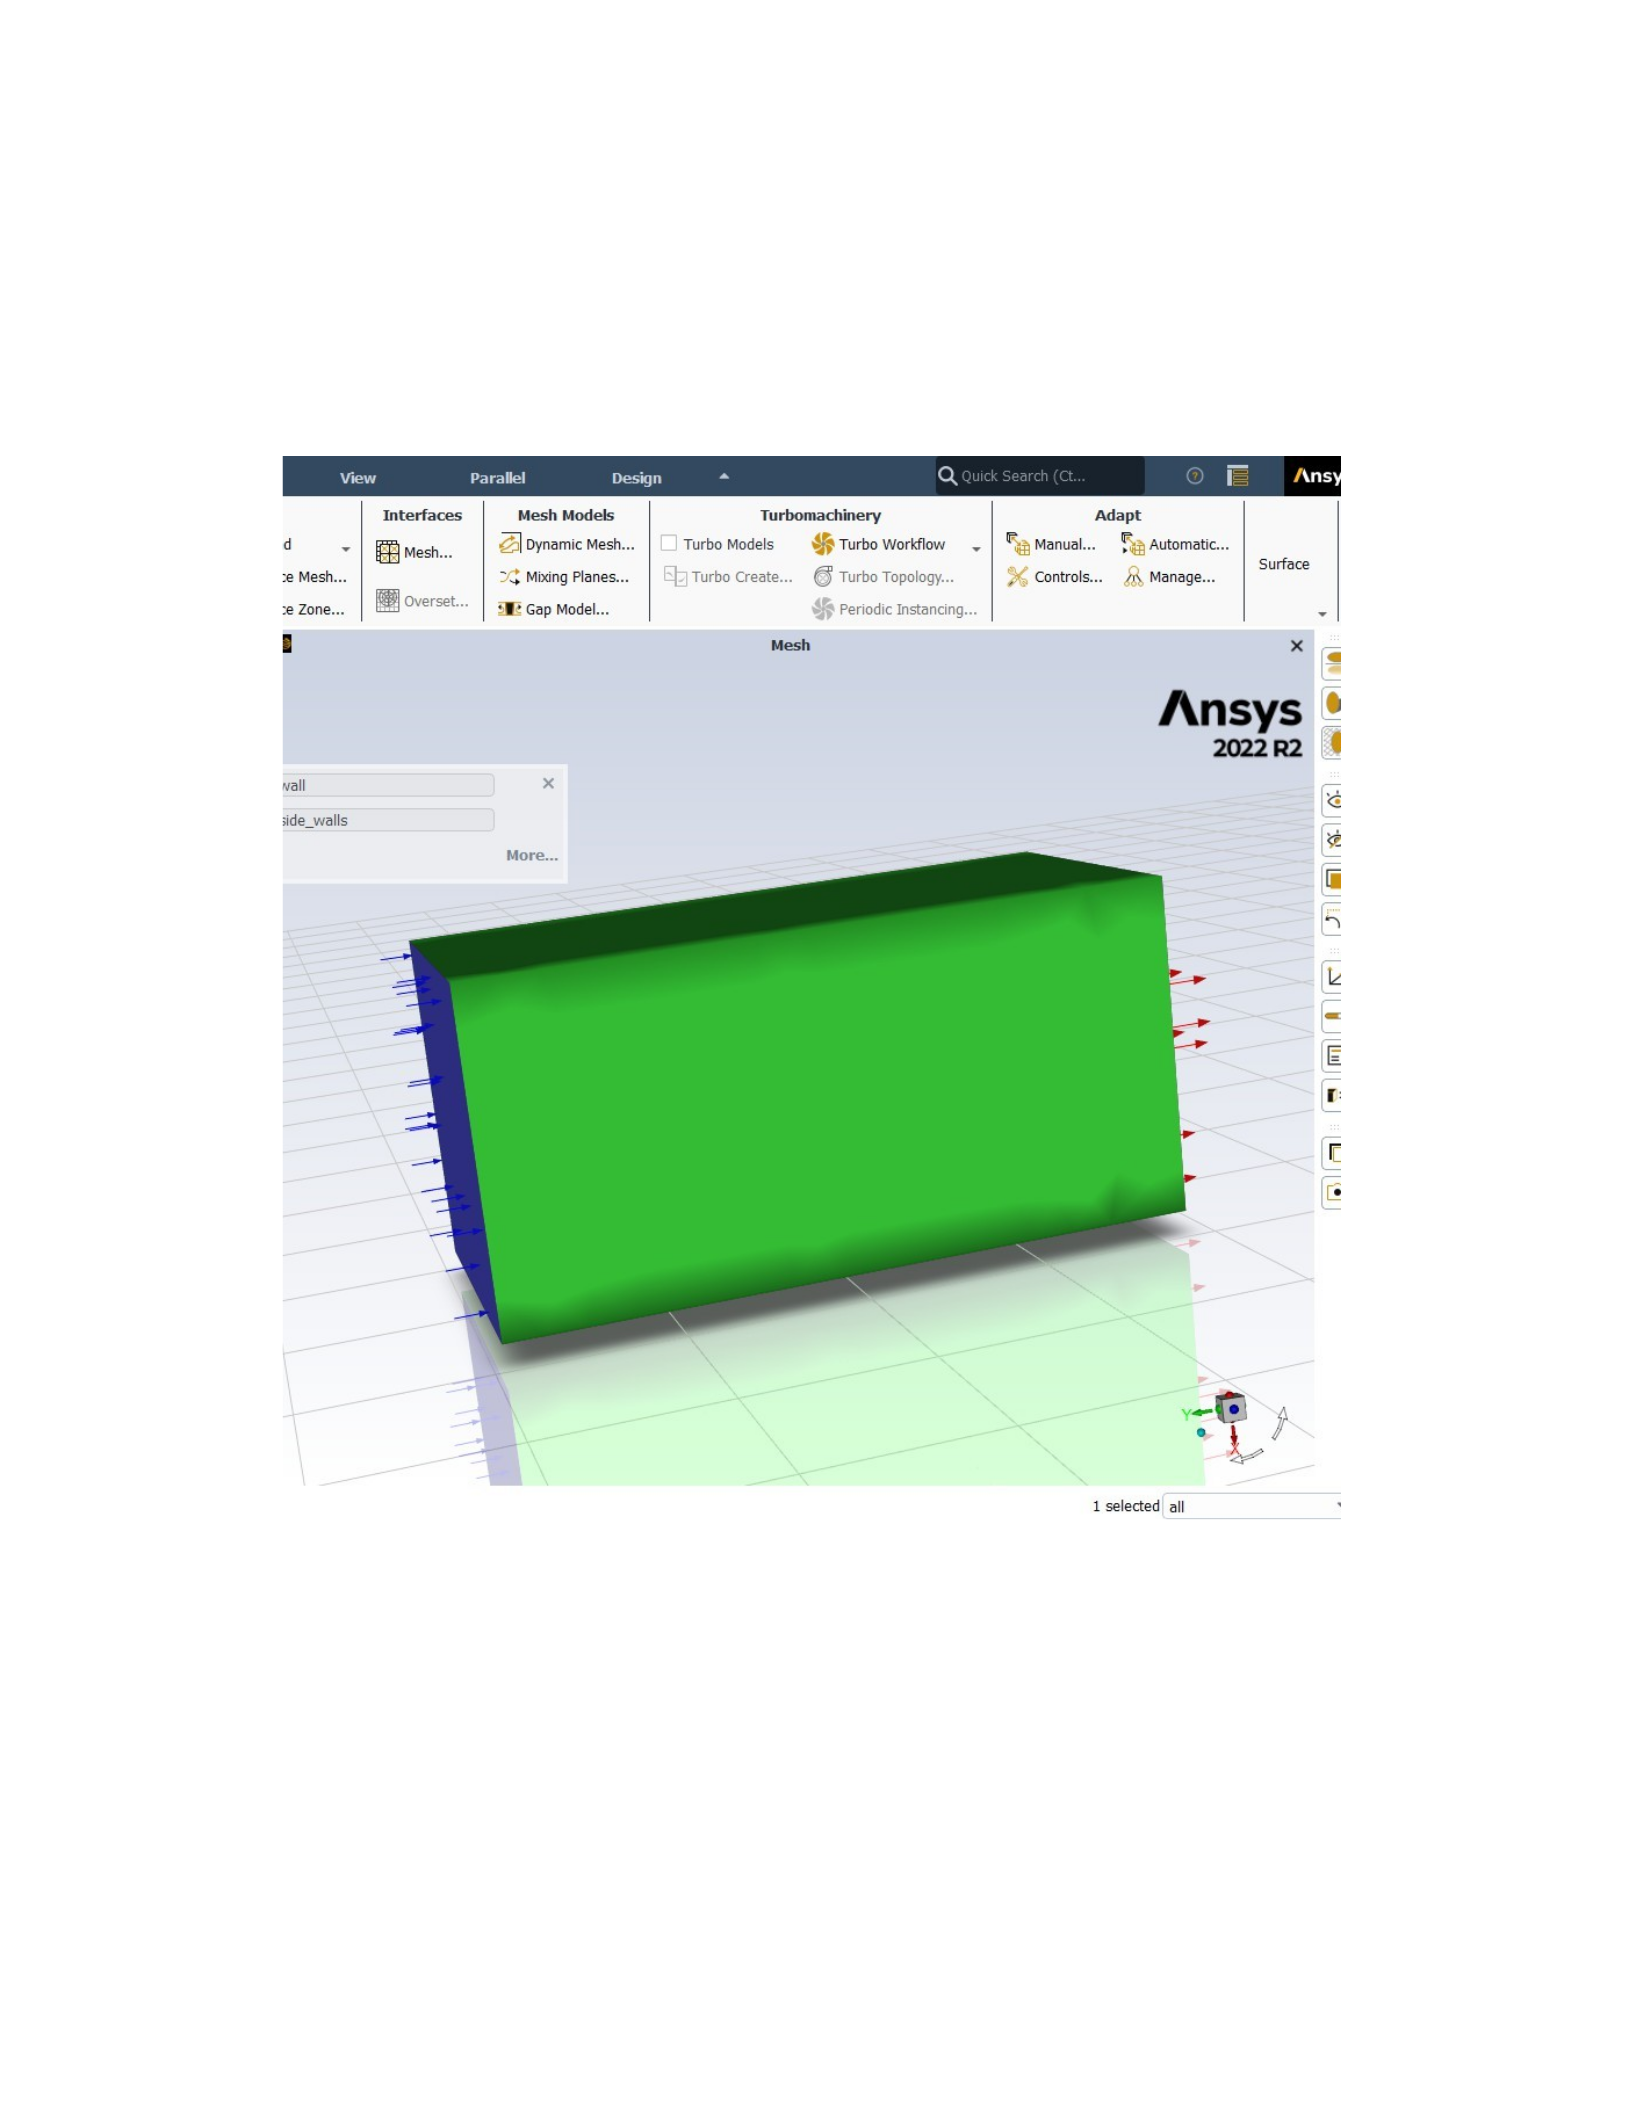
95
users to tailor the simulation to a specific engineering scenario. The correct imposition of these
boundary conditions ensures that the simulation faithfully replicates the physical behavior of the
system, allowing engineers and researchers to gain meaningful insights and optimize designs
with confidence. ANSYS' robust set of boundary condition options, coupled with a user-friendly
interface, empowers practitioners to create accurate and realistic simulations across a wide range
of engineering applications.
Figure 5.2 Creating the geometry of the towing tank and determining the inlet and outlet
directions.
In figure 5.2 the geometry of the towing tank based on the dimensions of the UNO towing tank
has been created, then the boundary conditions have been determined.
Meshing, a crucial step in the process of simulating computational fluid dynamics (CFD), plays
a crucial role in determining the accuracy and reliability of numerical results. In the realm of
ANSYS, the leading software suite for engineering simulation, mesh fabrication is a nuanced
and important task that involves discrete geometric domains into finite elements. Quality

96
and mesh suitability directly affects the simulation's ability to capture intricate details of fluid
flow, boundary layer phenomena, and other complex interactions in the simulation domain
(160-164).
To begin the meshing process in ANSYS, a geometric representation of the system under
consideration is imported into the pre-processing environment. These geometric models, often
generated using CAD software or imported from external sources such as SolidWorks, serve as
the basis for creating computational meshes. ANSYS provides a versatile tool for mesh creation
known as Mesh modules, which can be accessed through platforms such as Workbench or
ANSYS Meshing. The goal is to transform a continuous geometric representation into discrete
elements, facilitating the numerical solution of the governing equation (165-169).
A mesh is essentially a lattice that lines a computational domain, and its elements, or mesh cells,
can take various forms, such as tetrahedral, hexahereral, or polyhedral elements. The choice of
element type is influenced by the geometry of the system and the properties of the physics
involved (170-172). Tetrahedral elements, for example, are well-suited for complex geometries,
while hexaheredral elements are preferred for simplicity and computational efficiency. Creating
a suitable mesh requires a balance between capturing intricate details and maintaining
computational efficiency (173, 174).
The meshing process involves determining the density of the mesh, where a finer mesh
resolves more details but demands increased computing resources. Careful consideration
should be given to areas with high gradients or significant flow variations, as these areas may
require finer meshes to accurately capture the underlying physics. In addition, the boundary
layer, in which fluid flow undergoes significant changes in velocity and viscosity, demands
special attention. To address this, techniques such as boundary layer mesh can be used,
ensuring an enhanced mesh near the wall to accurately capture the velocity gradient.
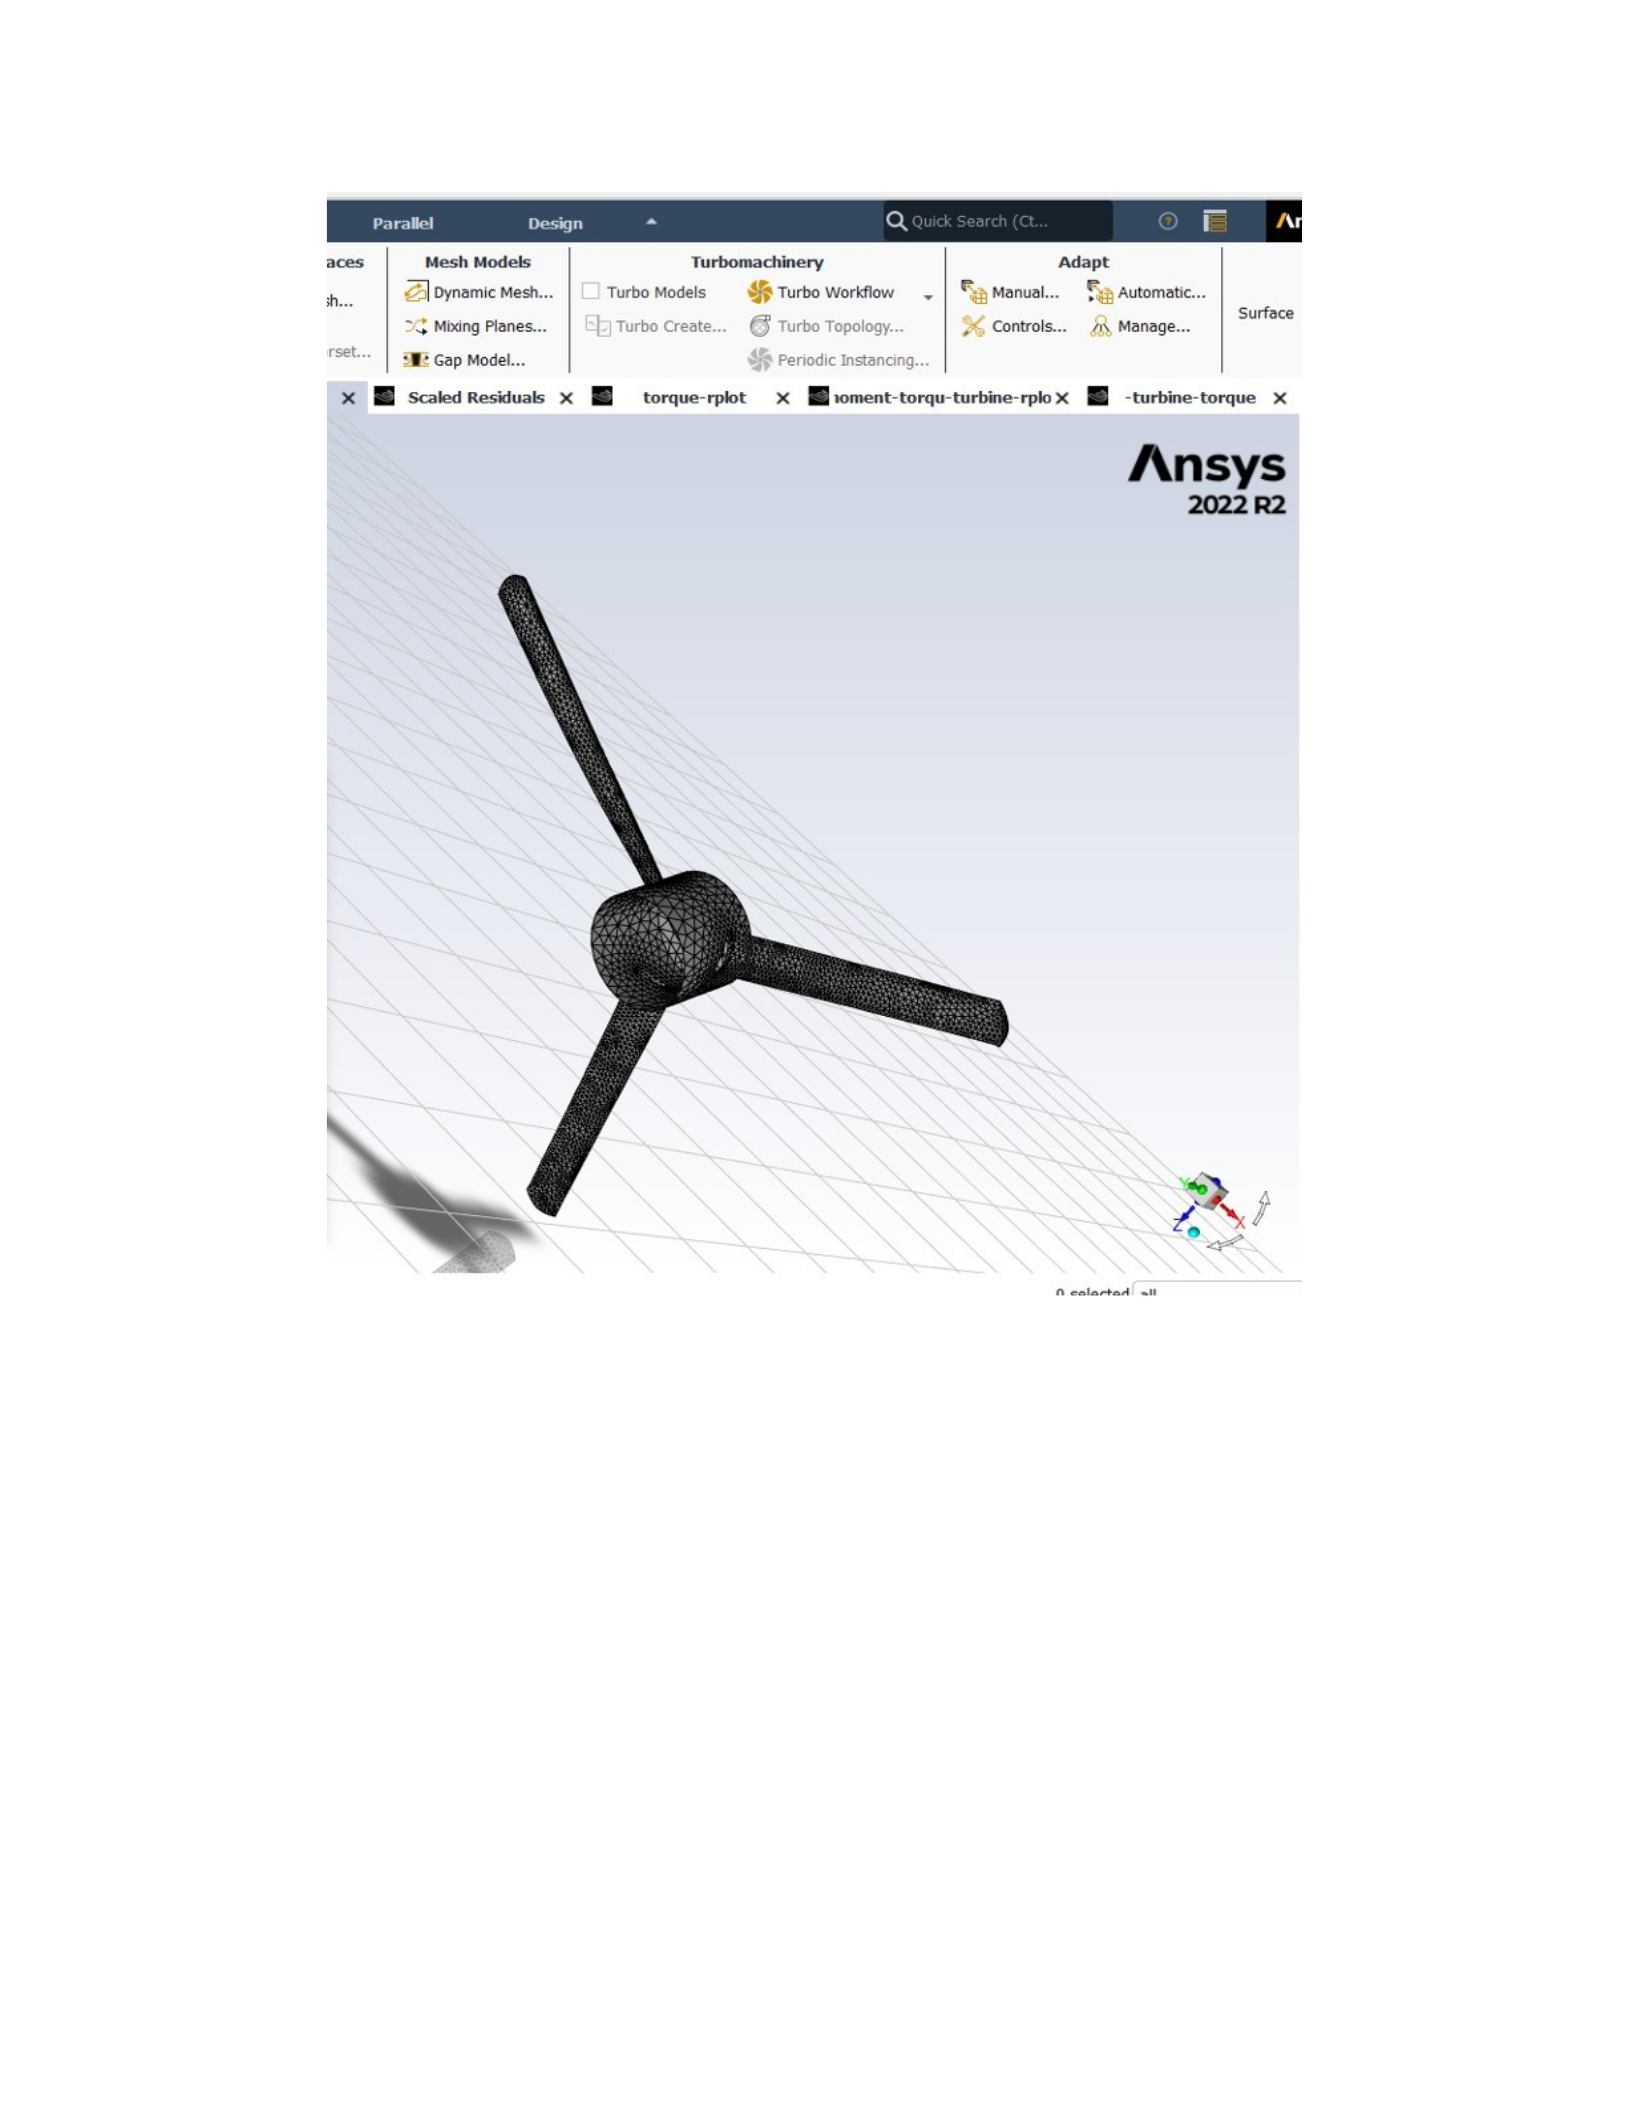
97
Figure 5.3 Meshing propeller.
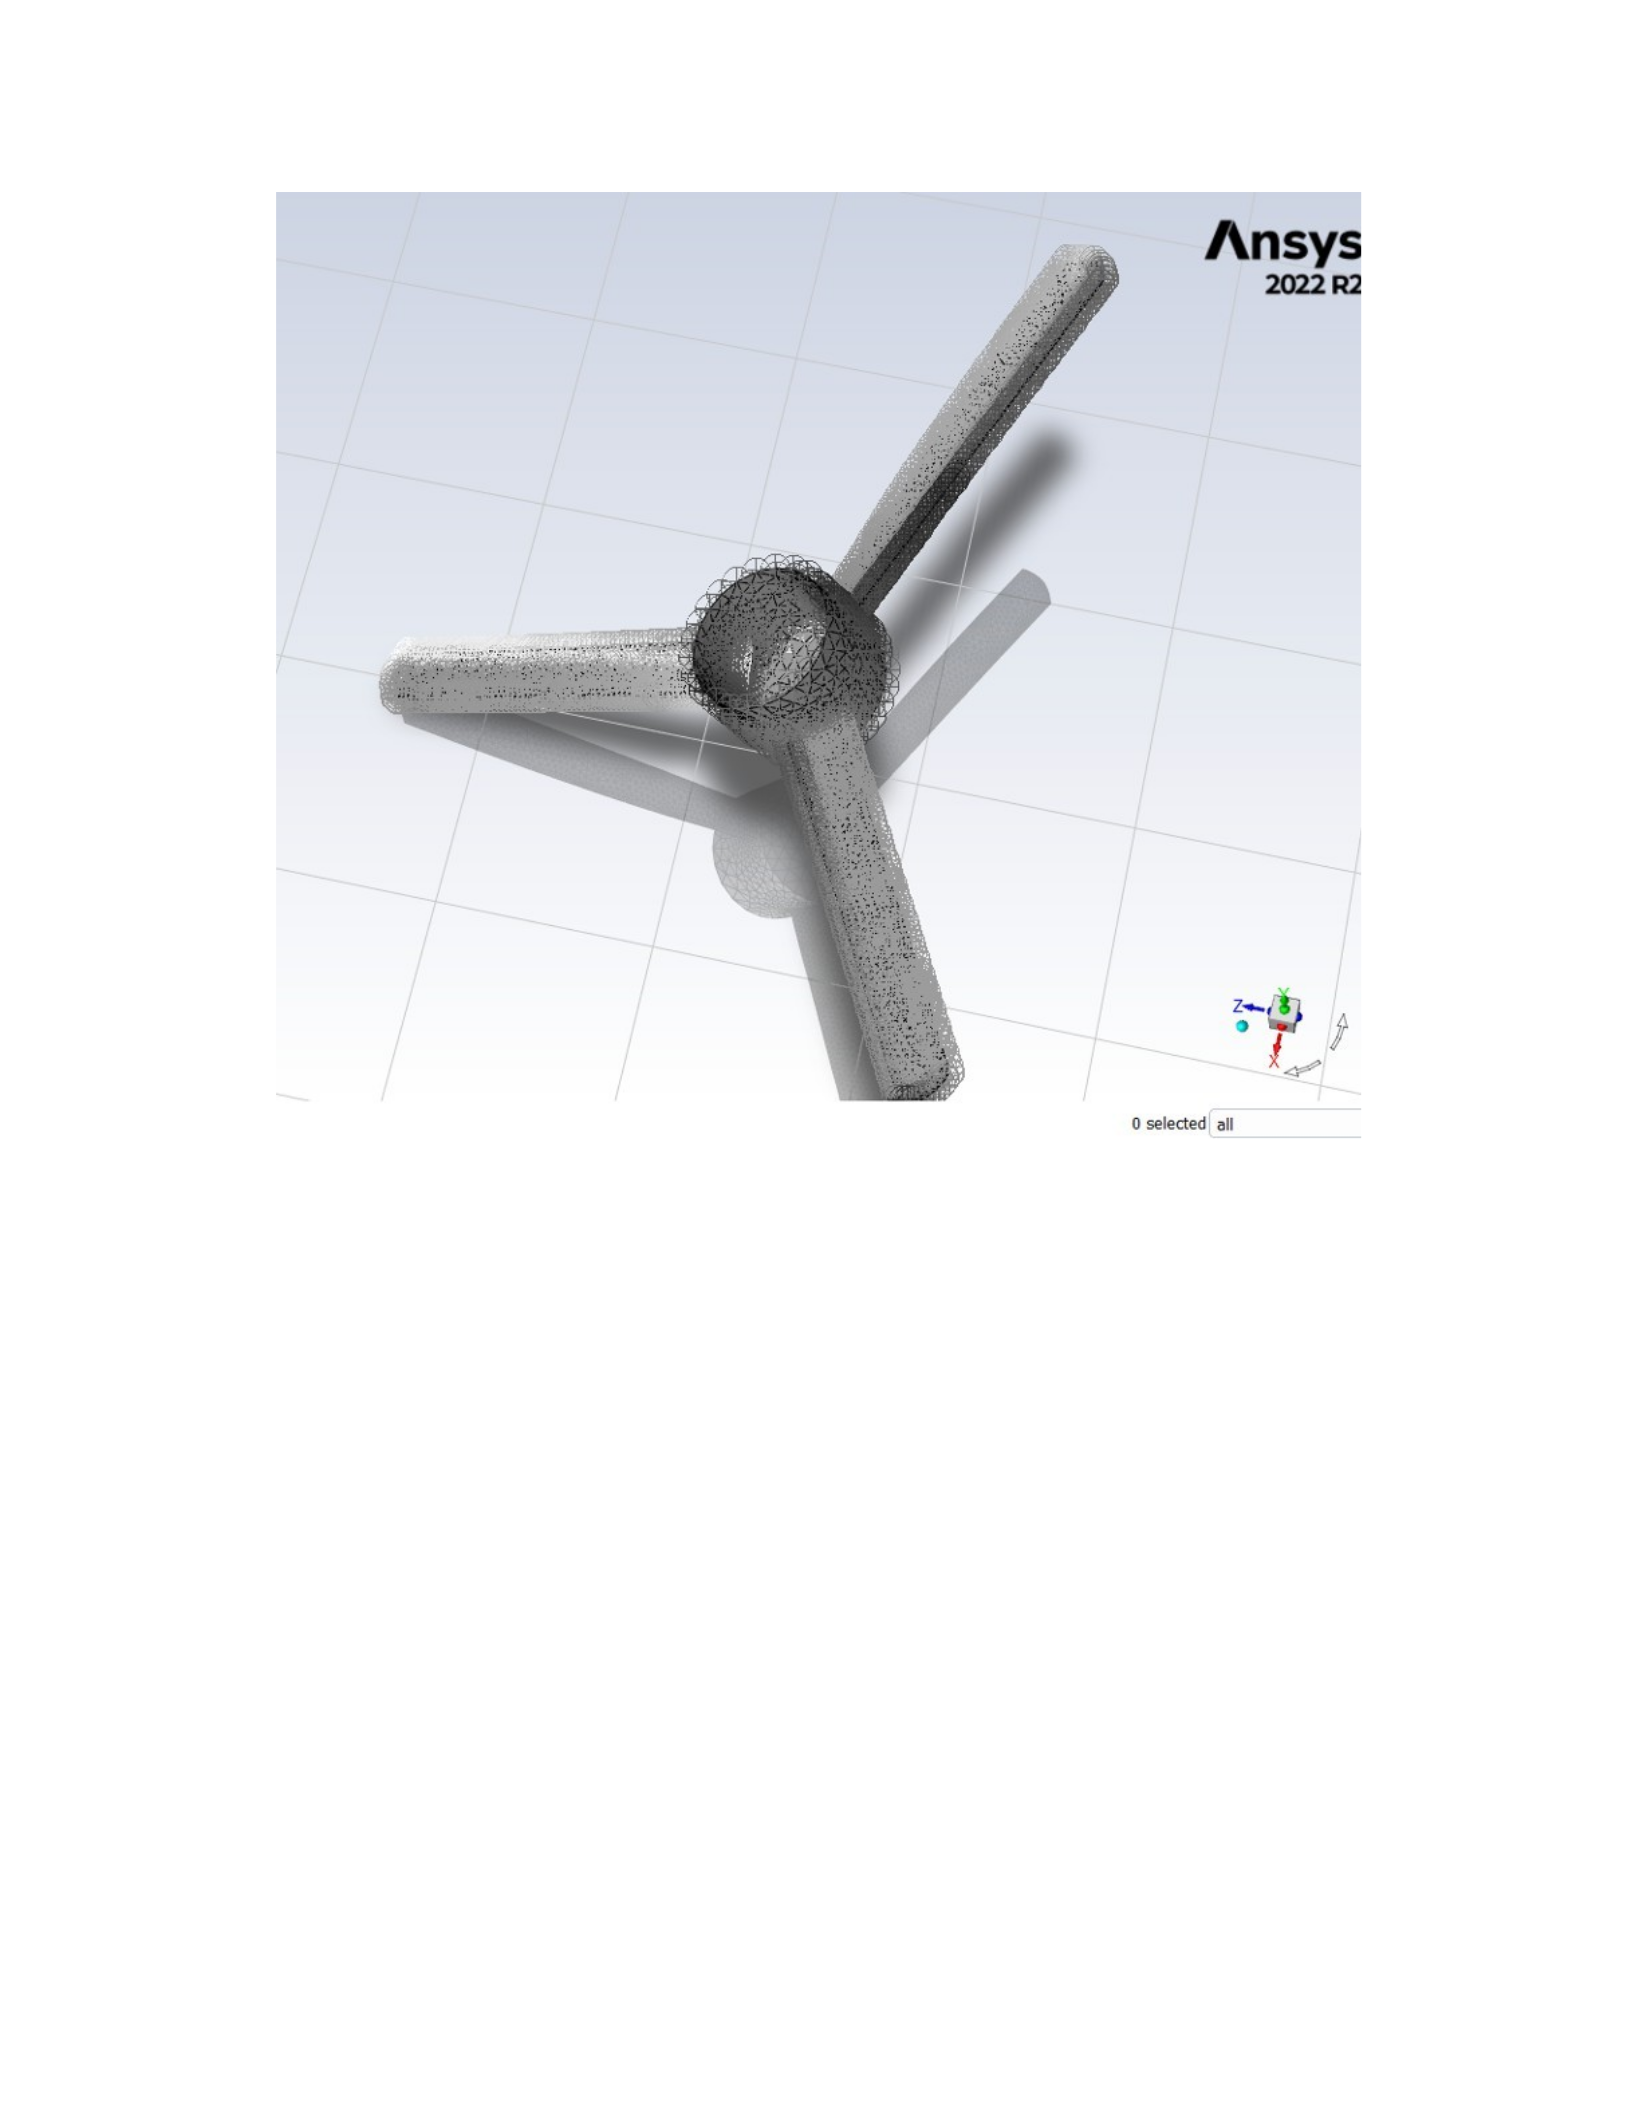
98
Figure 5.4 Meshing propeller from another view.
Figures 5.3 and 5.4 show how dense the propeller mesh has been determined.
In simulations involving complex geometries such as underwater turbines, it is common to use
meshes with varying levels of resolution to accurately capture flow characteristics.
For example, near the turbine body where the separation of flows, eddies, and other complex
flow phenomena may occur, a finer mesh with a smaller cell size will be required to accurately
complete the flow features. This high-resolution mesh helps to capture the effects of boundary
layers and turbulence near the body.
As we move away from the turbine body into a free-flow or far-terrain region, the mesh
resolution can be coarser because the flow is usually more uniform and less affected by the
boundary layer effect. This reduces computational costs while still maintaining accuracy in
simulations. The specific number of meshes and the distribution of mesh sizes will depend on
various factors such as turbine geometry, flow conditions, desired level of accuracy, and
available computing resources. It often requires some trial and error to determine the optimal
meshing strategy through mesh refinement studies and validation against experimental data or
benchmark simulations.
99
Figure 5.5 Propeller Meshing vs. Wall Meshing Blade.
Figure 5.5 visually illustrates the striking difference in mesh density between the propeller and
the towing tank wall. The propeller mesh shows a much denser and smoother configuration
compared to the mesh that surrounds the tank. This deliberate differentiation in mesh
enhancement is a strategic choice to accurately capture intricate details and complex flow
phenomena near the blade of the propeller. A finer mesh near the propeller ensures a more
precise representation of fluid dynamics, especially in areas where high gradients and complex
interactions are estimated. On the other hand, the coarser mesh around the wall of the towing
tank strikes a balance between computational efficiency and an accurate representation of
boundary conditions. This meshing strategy is a deliberate optimization that aims to achieve a
thorough understanding of the propeller's performance within a tow tank environment while
effectively managing computing resources.
Entry Speed (m/s) 0-2
Tekanan Outlet (Pa) 407500
Density (kg/m^3) 1006.4
Temperature (K) 295
Table 5.1
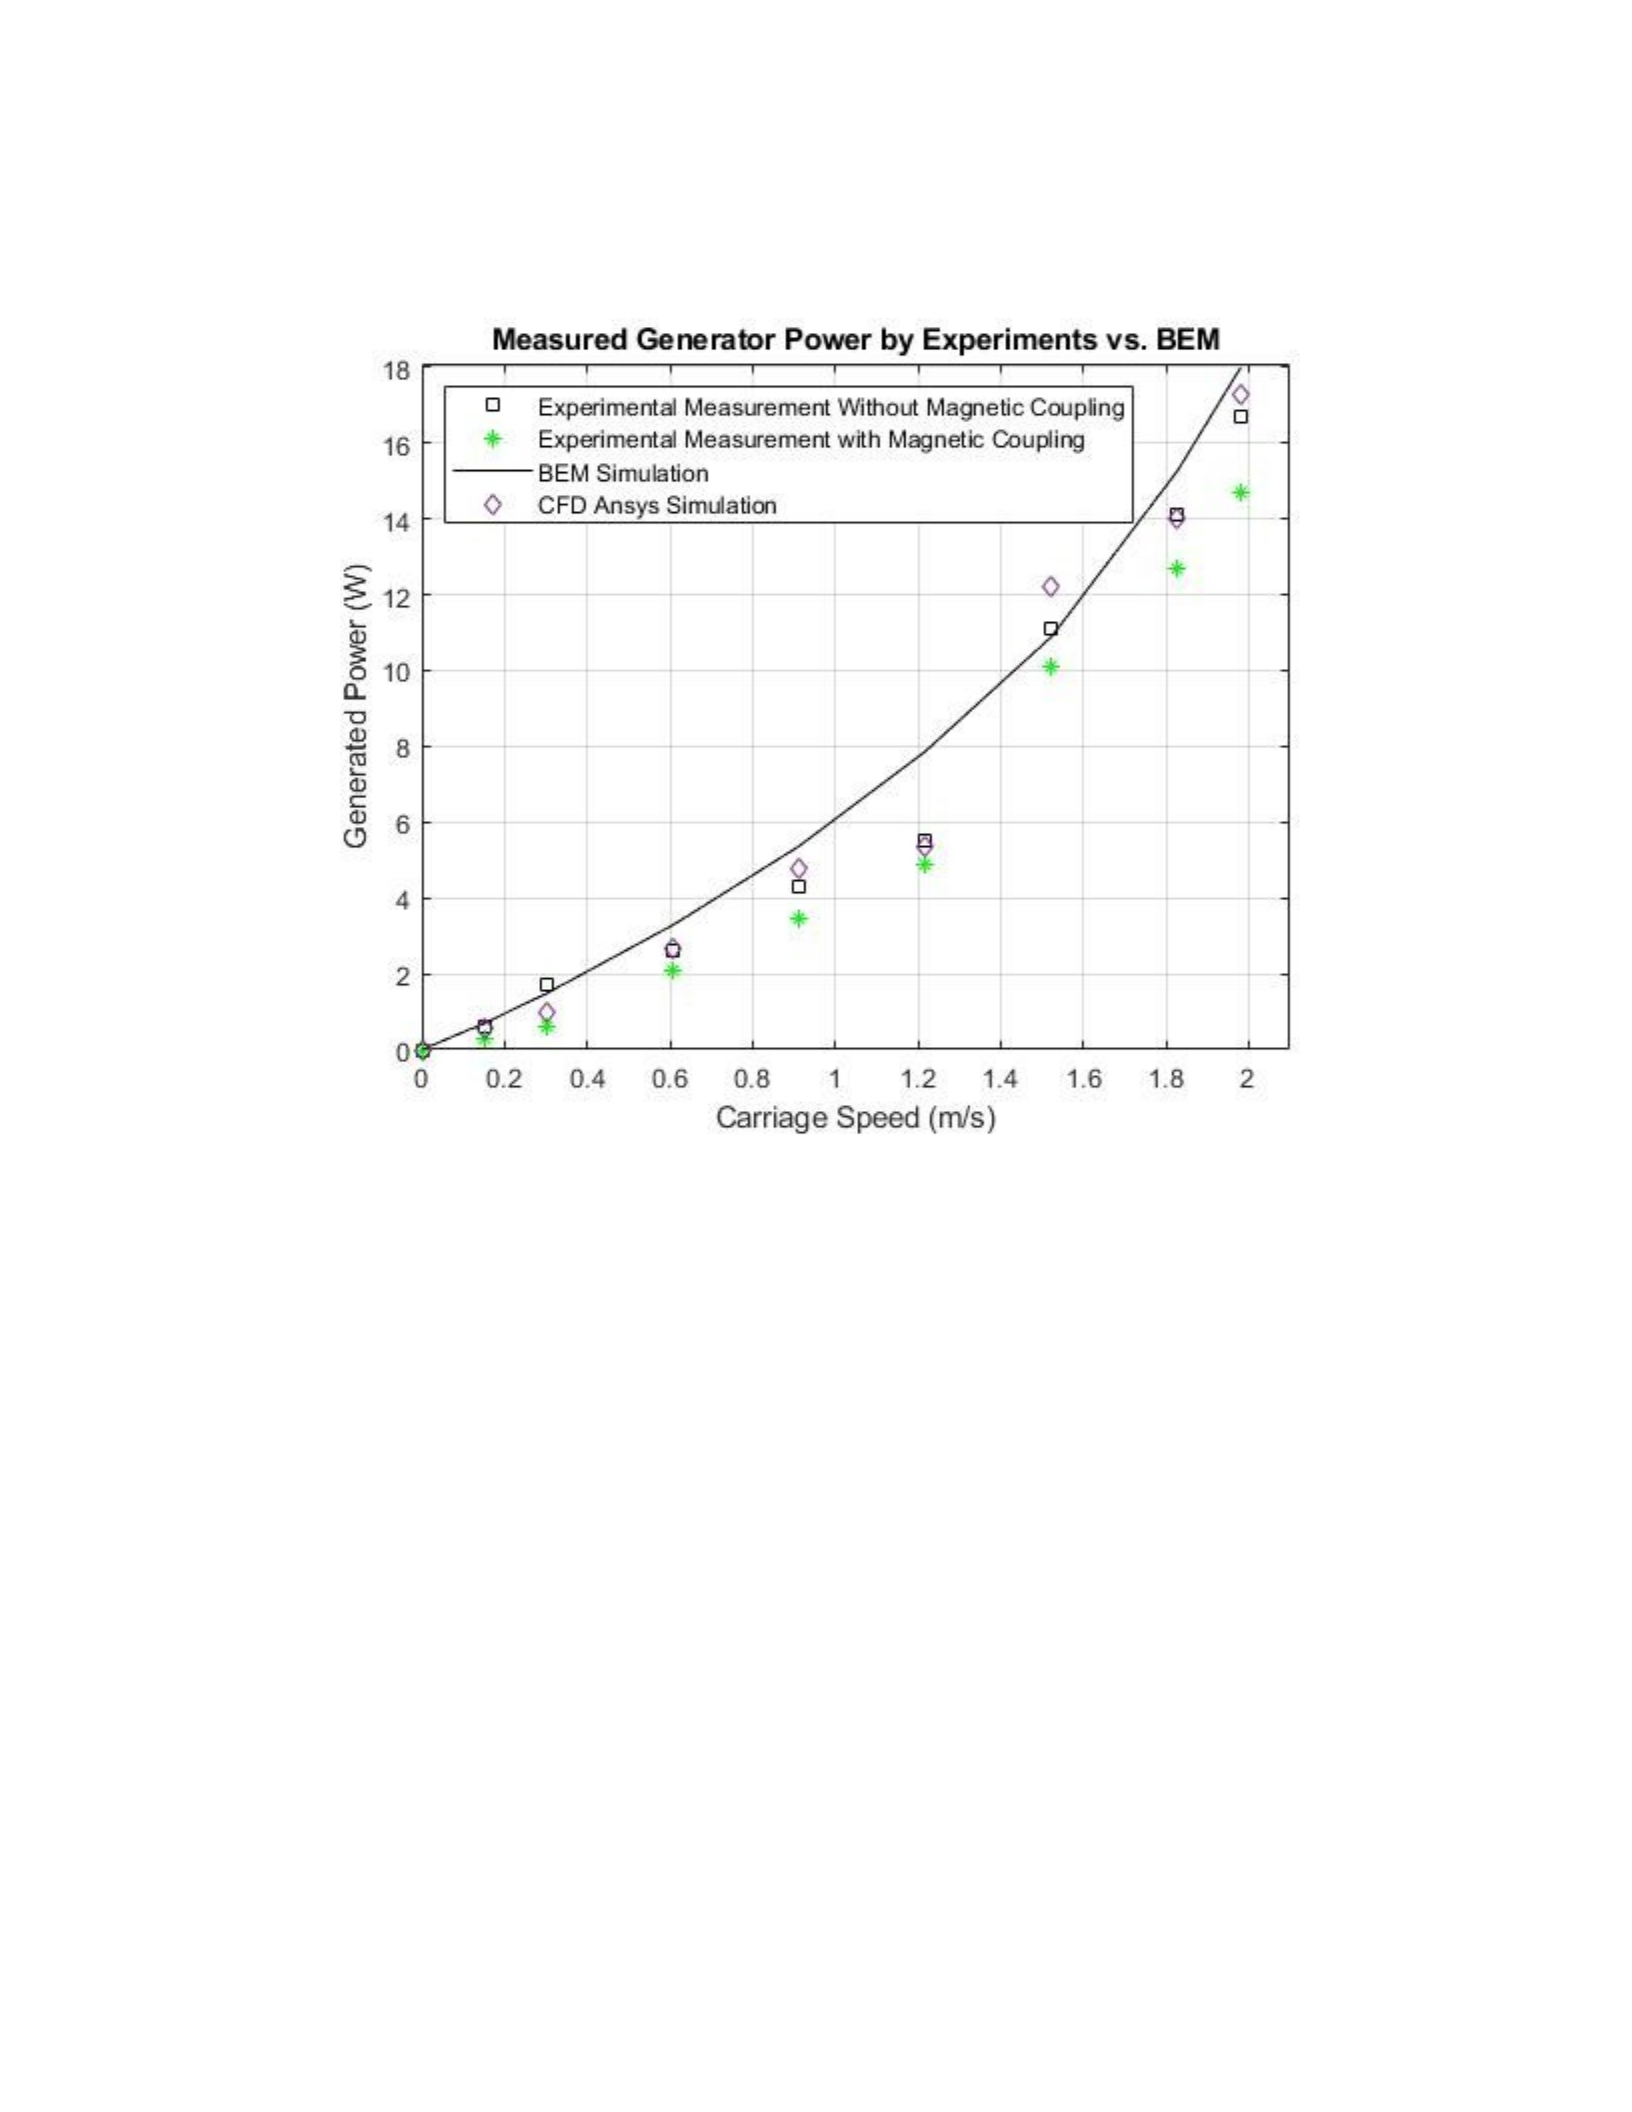
100
Table 5.1 shows the information behind the simulation such as inlet speed, outlet pressure,
water density and temperature.
Figure 5.6 Measured Power WITH Experiments with and without Magnetic Coupling VS. BEM
and Ansys Simulation
Figure 5.6 illustrates a comparative analysis of the power generated under various train speeds in
an experiment conducted with and without a magnetic clutch. This comparison was taken with
results derived from the simulation of Blade Element Momentum (BEM) and ANSYS Fluent
applied to Small Scale Ocean Current (OCT) Turbines. This investigation has yielded
noteworthy insights, demonstrating a commendable agreement between BEM and Ansys
simulations and experimental arrangements that integrate magnetic couplings, especially in the
context of train speeds ranging from 0 to 2 m/s.
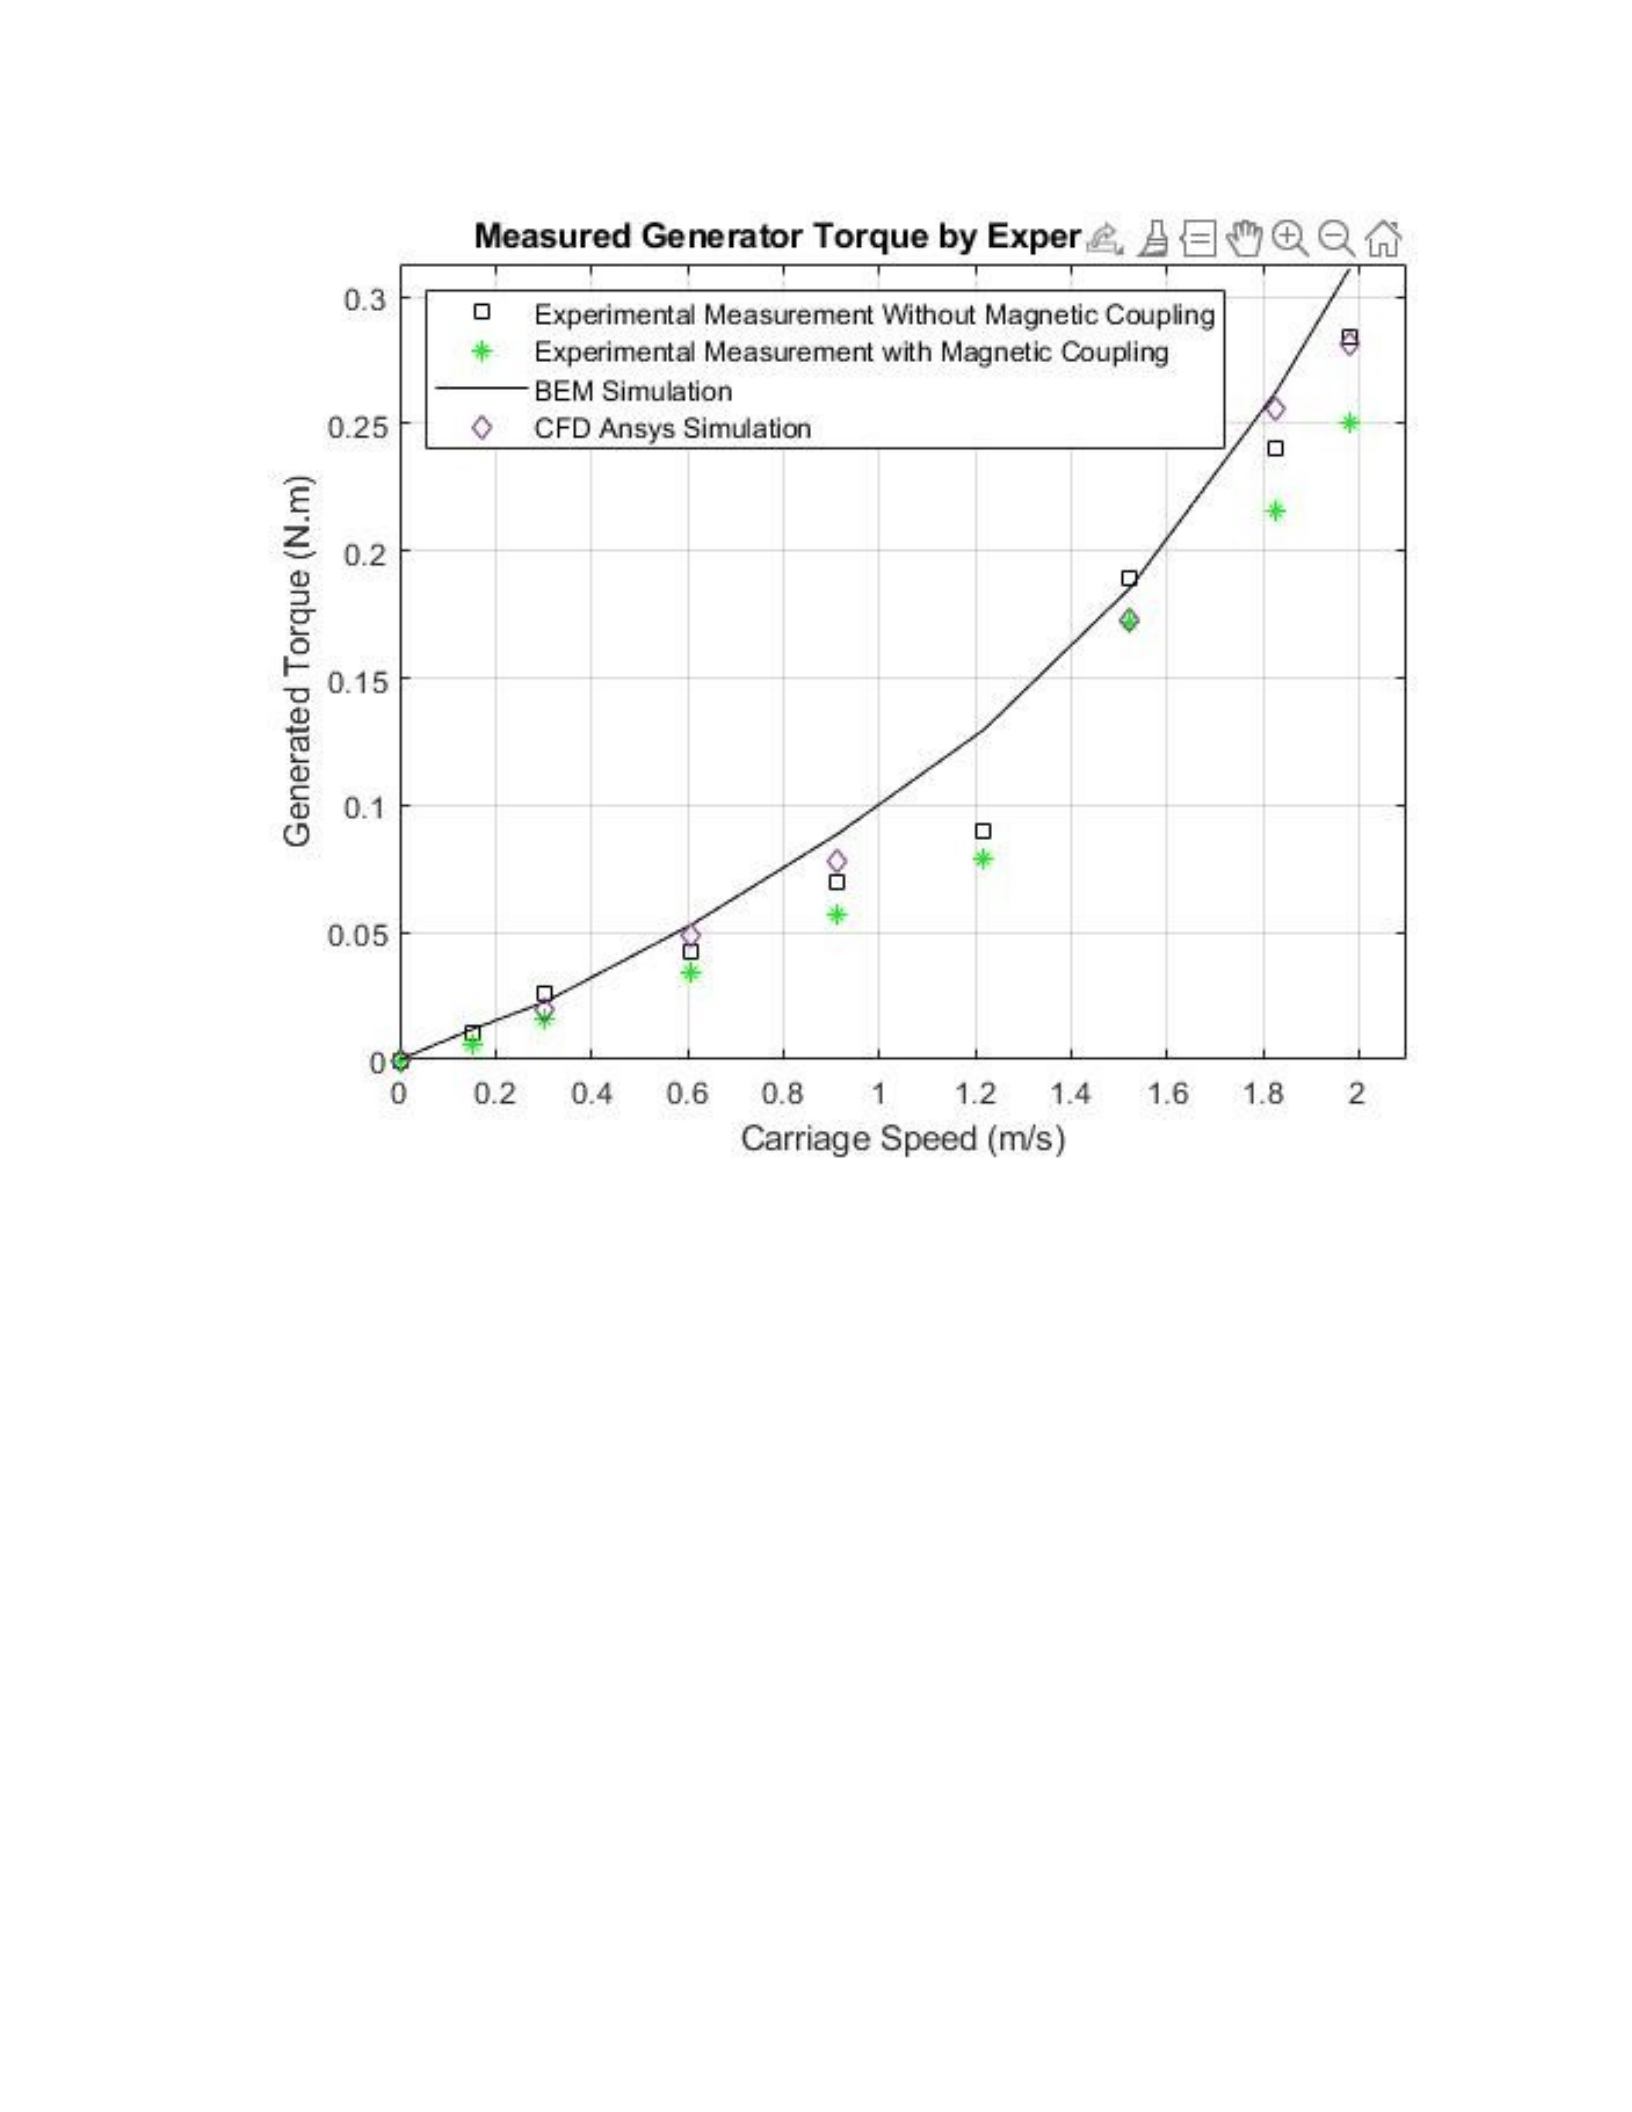
101
Figure 5.7 Measured Torque WITH Experiments with and without Magnetic Coupling VS. BEM
and Ansys Simulation
In Figure 5.7, a graphical depiction of the resulting torque measured versus train speed,
comparing experiments with and without a magnetic clutch, alongside predictions from Blade
Element Momentum (BEM) and ANSYS Fluent simulations for Small Scale Ocean Current
(OCT) Turbines, reveals an interesting trend. In particular, experimental results incorporating
magnetic couplings consistently showed the smallest torque values for each measured speed,
underscoring the effectiveness of magnetic couplings in minimizing torque generation. These
observations remain consistent when compared to BEM simulations and experiments conducted
without magnetic couplings.
In all three scenarios, there is an important and consistent agreement on torque values,
emphasizing the reliability and reproducibility of experimental data. This convergence in
torque results highlights the role of magnetic coupling as an important factor in regulating
torque at various train speeds, thus contributing to a more comprehensive understanding of the
performance characteristics of hydrokinetic turbines.

102
Ensuring the accuracy and correctness of a Computational Fluid Dynamics (CFD) model
involves several steps and considerations. Here are the steps used to validate and verify my CFD
simulation:
1. Validation against Experimental Data: Comparing the simulation results with
experimental data is a fundamental step in validating the CFD model. The close agreement
between the simulation results and the experimental data gives confidence in the accuracy of the
CFD model.
2. Grid Independence Study: Conducting a grid independence study involves running
simulations with different mesh resolutions to assess the sensitivity of the results to the mesh
size. By comparing results from different mesh resolutions, it is possible to determine the
optimal mesh size that provides accurate results while minimizing computing resources.
Convergence criteria are usually defined to ensure that the results are independent of mesh size.
3. Physical Understanding: A thorough understanding of simulated physical phenomena is
essential to ensure the correctness of the CFD model. It involves considering the underlying flow
physics, including the principles of fluid dynamics, boundary conditions, and turbulence
modeling. Models must accurately capture relevant flow physics, such as turbulence effects,
boundary layer behavior, and flow separation, based on well-established theory and empirical
knowledge.
4. Sensitivity Analysis: Conducting a sensitivity analysis helps assess the impact of key
parameters and assumptions on the simulation results. It involves various input parameters,
boundary conditions, or modeling assumptions to understand their effect on the outcome.
Sensitivity analysis helps identify potential sources of uncertainty and assess the robustness of
the simulation.
5. Peer Review and Collaboration: Peer review and collaboration with experts in the field of
fluid dynamics can provide valuable feedback and validation of the CFD model. Engaging in
discussions, sharing results with colleagues, and seeking input from domain experts help ensure
that simulation approaches and results are scientifically sound and aligned with established
practice.
Using these validation and verification techniques, along with a thorough understanding of
the underlying physics, I was able to ensure the accuracy and correctness of my CFD model,
thus gaining confidence in the simulation results and their application to real-world scenarios.

103
Conclusion
In conclusion, this dissertation is a comprehensive and innovative exploration of ocean
current turbine (OCT) technology, specifically focusing on the design, fabrication, and testing of
carbon fiber propellers for 3-blade horizontal axis OCT. The multifaceted nature of the study is
underscored by the strategic integration of cutting-edge technologies, starting with a careful
design phase using SolidWorks software. The utilization of SolidWorks facilitates the
examination of complex propeller geometry, allowing for nuanced structural optimization
tailored for optimal performance in the dynamic and challenging conditions presented by ocean
currents. The subsequent decision to create the propeller using carbon fiber, a material known for
its outstanding strength-to-weight ratio and corrosion resistance, exemplified a forward-thinking
approach to addressing the unique challenges posed by the marine environment. The
incorporation of 3D printing technology in the fabrication process not only demonstrates the
adaptability of modern manufacturing techniques, but also underscores the scalability potential
of the proposed solution for a wider range of applications in marine renewable energy systems.
This dissertation goes beyond theoretical discussion by basing its findings in practical
experiments, with the University of New Orleans' towing tanks providing a controlled and
realistic environment for testing propeller performance under simulated ocean current conditions.
The tow tank experiments, which were carefully conducted and analyzed, produced results that
not only confirmed the efficacy of the propeller, but also showed a remarkable fit with
predictions derived from the Blade Element Momentum theory and Ansys Fluent simulations.
This harmonious alignment between theoretical models and real-world experiments builds a
solid foundation for the practical application of propellers designed in the context of ocean
energy extraction. The success of the propeller design, validated through a rigorous and
multidimensional approach, goes beyond its immediate implications, offering valuable insights
into the broader landscape of marine renewable energy research and development. This
dissertation critically examines the implications of the research findings, both in terms of
advancing OCT technology and contributing to the broader narrative of sustainable energy
solutions. The comparison between the experimental results and the numerical model provides a
detailed and nuanced understanding of the dynamics of the propeller, explaining the strengths
and limitations of each model. This critical analysis not only improves our understanding of
specific propeller designs, but also contributes to the ongoing discourse on optimizing turbine
designs for ocean energy extraction. In addition, the success of multidimensional investigations,
combining theoretical predictions, advanced manufacturing techniques, and empirical validation,
establishes a comprehensive framework that can be replicated and adapted for future research
efforts in the field. Designed carbon fiber propellers are emerging not only as components of
OCT but as real solutions, beacons that guide future researchers, engineers, and policymakers in
the relentless pursuit of sustainable energy sources. Beyond direct technological advancements,
this research resonates with the global imperative to transition towards cleaner and more
sustainable energy alternatives. By showcasing the potential of ocean current turbines and
providing a robust methodology for their design and validation, this dissertation contributes to
broader efforts to mitigate climate change and secure a more sustainable future. The success of
the propeller design is not only a scientific achievement but a beacon of hope, signaling that with
innovation, collaboration, and the relentless pursuit of excellence, humanity can harness the
immense energy potential inherent in our oceans to power a cleaner and brighter tomorrow.

