


1
ASSESSING THE INFLUENCE OF RELATIVE WINDS OVER THE DECK ON MH-60S
HELICOPTER OPERATIONS: A FOCUS ON SHIPBOARD LAUNCH AND RECOVERY
I. INTRODUCTION
1. BACKGROUND
Cuts to the U.S. armed forces after the Cold War have prompted senior
military leadership to seek more efficient, safe, and cost-effective ways to
maintain the strength and superiority of the force despite budget cuts. Within the
Department of Defense (DOD), the acquisition process has undergone a complete
restructuring, which includes research and development, testing, procurement of
products, and delivery for use. In the U.S. Navy, the immediate impact of these
cuts is seen in the decline in the number of ships, submarines, and aircraft
available for national defense.
In the field of naval aviation, the U.S. Fleet Commander has drafted the Naval
Helicopter Master Plan (HMP), which aims to support the flight of naval
helicopters in the process of necessary trimming. HMP "provides a roadmap for
the modernization and revitalization of the naval helicopter force through 2020"
(Operational Requirements Document, 1998), and details the reduction of existing
helicopter types/models/series (T/M/S) from eight models (SH-60B, SH-60F, HH-
60H, CH-46D, SH-3, SH-2G, UH-1N, and MH-53E) to two models (SH-60R and
MH-60S). "The reduction to two similar helicopter models, with the components
sharing the most in common, would result in significant savings for the Navy in
terms of both acquisition costs and operating and support costs" (Operational
Requirements Document, 1998). An additional advantage of this reduction in

2
T/M/S is increased combat capability, as well as reduced manpower and
infrastructure requirements. Component commonality, cost and labor reductions,
and optimization of supporting infrastructure will be greatly facilitated by the
similarities in the airframe and key components, and most importantly, with the
implementation of Common Cockpit (CC), a fully integrated and software-
supported glass cockpit, to be installed on the SH-60R and MH-60S (Operational
Requirements Document, 1998).
According to HMP, the MH-60S is scheduled to replace most of the Navy's
existing helicopters (HH-60H, CH-46D, SH-3, UH-1N, MH-53E) while the SH-
60R will replace the other models (SH-60B, SH-60F, and SH-2G). The first step
in the replacement of these helicopters was the introduction of the MH-60S,
which was designed to replace the aging H-46D Sea Knight from the 1960s, given
its high maintenance needs, limited operating radius, lack of severe weather
capabilities, and low combat resistance. This replacement requires the application
of technologies that can reduce pilot workload, increase multi-mission
effectiveness, improve aircraft reliability, maintenance, and availability, and
enable the development of future system technologies (Operational Requirements
Document, 1998).
The process of developing, testing, and deploying the new airframe has
reached the testing stage, and the operational deployment of this much-needed
replacement is scheduled for 2002. MH-60S test efforts are currently underway at
the Navy's Rotary-Wing Aircraft Test Squadron and at the One Operational Test
and Evaluation Squadron designed to evaluate the aircraft as a direct form, fit and
functional replacement for the H-46D as currently in use in the fleet
3
in the Search and Rescue mission of the Vertical Replenishment and Amphibious
Ready Group (ARG). With the successful replacement of all H-46D helicopters,
the SH-3 and UH-1N helicopters will be replaced. Advanced MH-60S testing is
designed to support the integration and deployment of the systems required in the
next steps of HMP, the replacement of MH-53E in 2005, and SH-60F and HH-
60H in 2006.
Thus, the United States Navy's newest helicopter, the MH-60S multi-mission
Sea Hawk, is now in the final stages of the testing process and will begin fleet
operations aboard naval ships in late 2002. The MH-60S helicopter's requirements
for operating in a ship's environment have required a detailed evaluation of the
helicopter on board, and include the development of a launch and recovery wind
shield designed to enable safe ship operations aboard all naval vessels without
significantly compromising operational capability or flexibility.
2. TESTING OBJECTIVES
The purpose of this test was to investigate the effects of relative wind above
deck on MH-60S helicopters during launch and recovery operations aboard LHD
1, T-AFS 1, and T-AFS 8 class ships. Quantitatively, the objective of this
investigation is the development of operationally flexible launch and recovery
wind envelopes for MH-60S helicopters aboard these ships.
4
3. DESCRIPTION OF TEST AIRCRAFT: MH-60S SEA HAWK
The MH-60S helicopters, presented in Figures A-1 and A-21, are
manufactured by Sikorsky Aircraft Corporation (SAC), Stratford, Connecticut.
The aircraft is a twin-engined single-main rotor helicopter designed to perform the
main missions of vertical replenishment (VERTREP) of ongoing fleet assets, fleet
logistical support, and combat group search and rescue (SAR). The aircraft is also
designed to allow for future growth of the system to support additional primary
missions of combat search and rescue (CSAR), air mine countermeasures
(AMCM), ground special warfare support (SWS), and anti-surface warfare
(ASUW).
The MH-60S helicopter is a blend of the current Sikorsky H-60 components,
but it also includes the incorporation of several unique systems and components.
The aircraft is built primarily from the U.S. Army's UH-60 Black Hawk fuselage,
and is equipped with U.S. Navy SH-60 Sea Hawk mechanical components,
automatic flight controls, and dynamics.
The fuselage consists of three main parts, the cockpit, the cabin compartment,
and the tail mast. The cockpit houses two pilots, and each pilot station allows
access to the full instruments and flight controls of a conventional helicopter. The
fuselage incorporates a system of non-retractable landing gear consisting of fixed
right and left main landing gear, and a swivel-type tail gear.

5
The MH-60S aircraft is equipped with a fully articulated SH-60 main rotor
system. The four main rotor blades are mounted on hinged spindles maintained by
elastomer bearings, all contained in a one-piece titanium hub. Elastomeric pads,
two per blade, are designed to allow the blades to pack, lead, lag, and change
pitch. Flight control movements are transmitted to the rotor blades through the
main rotor head, which uses bell cranks, swash plates, and pitch control rods to do
so. Cycle, collective, and pedal controls are mechanically combined in a mixing
unit designed to ensure aircraft response characteristics that are not coupled with
flight control inputs, prior to the main rotor head. The rotor system is equipped
with a hydraulic rotor brake system designed to prevent the rotor system from
spinning during engine start and to provide quick shutdown. Anti-torsion and
direction control on the MH-60S is provided by a bearing-free crossbeam tail
rotor system. The movement of the tail rotor blade (flap and pitch change) occurs
with the deflection of the flexible graphite blade spar. The tail rotor is a tractor
type, on the right side of the aircraft, and tilts 20 upwards (providing about 2.5%
of the total lift while hovering). Both the main rotor system and tail are designed
to be folded, the main rotor system automatically, and the tail rotor system
manually, for ship storage.
The authority of the tail rotor depends on the impressed pitch of the tail rotor
(the angle of the actual tail rotor blade). The pitch of the tail rotor is dependent,
not only on the pedal position, but the collective position (due to the collective-to-
yaw mixing), the stability augmentation system (SAS) inputs, and the difference
in the individual aircraft rigging, nothing is fed back to affect the pedal position.
To provide

6
The left pedal margin is additional and allows operation at gross weight and high
density altitudes, and since American-made helicopters usually do not have the
right pedal margin problem, the pitch seems the tail rotor is biased to the left side.
This bias has traditionally been 1.5 on U.S. Navy helicopters, however, a 3
tail rotor bias is being explored for fleet implementations (the U.S. Army, U.S.
Air Force, and U.S. Coast Guard all currently use a 3 tail rotor bias). With a tail
rotor bias of 1.5, the pitch of the tail rotor impression available ranges from the
right bar angle of 14 to 17 left. With a tail rotor bias of 3, the impression
pitch of the available tail rotor ranges from the right blade angle of 12.5 to
18.5 left (in the unbiased condition, the blade angle of 15.5 is available both
left and right).
The MH-60S transmission system is designed to combine the power output of
the two engines, reduce the rotational speed, and transfer power to the main and
tail rotors. In addition, the transmission system provides power generation and
hydraulics. Each engine is an upgraded T700-GE-401C engine that provides a
maximum continuous power of 1662 SHP, medium power of 1800 SHP (for 30
minutes), and contingency power of 1940 SHP (for 21/2 minutes). Fuel for the
main engine and auxiliary power unit (APU) is provided by a collision-resistant
suction type fuel system, which includes two main fuel cells with a total usable
capacity of 360 gallons (approximately 2448 lbs. JP-5).
The MH-60S hydraulic system is designed primarily to provide up to 3000 psi
hydraulic pressure to the main servos, main rotor and tail rotor, pilot assist servos
and trim actuators. The aircraft incorporates an electro-hydromechanical
automatic flight control system (AFCS) designed to
7
provides flight control inputs for added stability; stabilizer control; Trim; attitude,
direction, airspeed and altitude held; and combined approach, hover and take-off
capabilities (A1-H60SA-NFM-000, 2002).
A complete and detailed description of the MH-60S helicopter can be found at
A1-H60SA-NFM-000, Naval Air Operations Training and Procedures
Standardization Flight Manual, Naval Model MH-60S Aircraft.
Two MH-60S aircraft, Bureau Number (BuNo) 165742 (aircraft #1) and
BuNo 165744 (aircraft #3), were flown during this evaluation. BuNo 165742 is a
production representative with the exception of the following components: (1) an
advanced data recording package that enables telemetry (and recording) of aircraft
data and parameter monitoring in real time during test events; (2) 150 lbs. of
weights mounted on the nose in place of the Instrument Landing System (ILS)
antenna for center of gravity (CG) management; and (3) 3 of the vice tail rotor
bias of 1.5. BuNo 165744 is a production representative of the MH-60S, which
is uninstrumented, combines a ballast package with an ILS antenna, and has a tail
rotor bias of 1.5.
4. DESCRIPTION OF THE MH-60S COMMON COCKPIT
The Common Cockpit (CC) was built by Lockheed Martin Federal Systems
(LMFS), Owego, New York. Designed for use on the MH-60S and SH-60R
helicopters in support of the Helicopter Master Plan, the CC is the U.S. Navy's
first "all-glass" digital cockpit (Figures A-3 and A-4). CC incorporates two
multifunctional flight displays (Figure A-5), two multifunctional mission displays,
two sets of keys, a communication subsystem, a navigation subsystem, and a
8
manual Operator input/output panel. Each flight view provides key flight and
navigation information, and each mission view provides geosituational and
navigation information, as well as aircraft systems and diagnostic information.
Interface with the system through two sets of keys located on the lower center
console. The main communication and navigation subsystems available include:
Embedded Global Positioning System (GPS) Inertial Navigation System (INS)
(EGI); Ultra and Very High Frequency (UHF/VHF) plain/secure communications
and satellites; Tactical Airborne Navigation (TACAN), Very High Frequency
(VHF) Omni-directional Radio Range (VOR), Instrument Landing System (ILS),
and Low Frequency/Automatic Direction Finding (LF/ADF) navigation (A1-
H60SA-NFM- 000, 2002).
5. DESCRIPTION OF TEST VESSEL
i. United States Ship BATAAN (LHD 5)
USS BATAAN (Figure A-6), one of five ships in the WASP class (LHD-1), is
an amphibious assault ship designed to launch, deploy, and land elements of the
Marine Amphibious Ground Task Force with a combination of helicopters and
amphibious landing ships. Each ship is 844 feet long, has a 106-foot waterline
block, a 27-foot draft, and moves about 40,500 tons with full load. Two
Combustion Engineering boilers, two Westinghouse geared turbine engines, and
two propeller shafts are designed to propel WASP-class vessels up to 24 knots
producing 77,000 SHP. The LHD-1 class ships are designed with a full-length
flight deck that is 819 feet long and 106 feet wide,

9
a large aircraft hangar under deck, two aircraft elevators, several vehicle storage
areas below deck, and a floodable well deck for amphibious landing craft and air-
cushioned vehicles. The flight deck, equipped with Night Vision Device (NVD)
compatible lighting, is approximately 60 feet above the ship's waterline, and
incorporates nine marked helicopter landing spots. Near the landing place of this
flight deck is a very large ship superstructure located in the middle of the ship, on
the right side. Designed primarily to provide structural requirements for all
operating rooms above flight deck level, it also incorporates a complex array of
antennas, exhaust stacks, and other structural elements.
The LHD-1 class ships are designed to be deployed with the following aircraft
complements: 30 CH-46 Sea Knight and CH-53E Sea Stallion helicopters and 6
AV-8B Harrier jets. The crew consisted of 62 officers and 1084 enlisted men, and
berthed up to 1685 Marines were available, as well as medical facilities for up to
600 patients (Polmar, 1997; NAEC-ENG-7576, 2001).
ii. United States Navy ship CONCORD (T-AFS 5)
The USNS CONCORD (Figure A-7), one of five ships in the MARS class (T-
AFS 1) operated by the Military Sea Transport Command (MSC), is a combat
storage ship designed to provide replenishment of supplies at sea (food, mail,
ammunition, etc.) via tensioned cargo rigs and helicopters. Traditionally, two H-
46 helicopters are usually boarded on ships. Each ship is 581 feet long, 79 feet
wide, has a draft of 24 feet, and moves about 18,663 tons with full load. Three
Babcock & Wilcox boilers, 1 De Laval turbine (Westinghouse in TAFS 6), and
one propeller shaft designed to propel MARS-class ships up to 21 knots by

10
yielded 22000 SHP. The T-AFS 1 class ships combine a rear flight deck that
houses one helicopter during launch and recovery, and a hangar designed to
accommodate 2 folded helicopters. The flight deck is about 68 feet long and
between 50 feet (rear) and 72 feet wide (front). The deck is marked and
illuminated for inclined and right harbor approaches and 34 feet above the water
level. The USNS CONCORD combines night lighting packages and NVDs for
landing operations and VERTREP. Near (just ahead) the flight deck is a very
large ship superstructure. Designed primarily to provide structural requirements
for all operating rooms above flight deck level, it also incorporates a complex
array of antennas, exhaust stacks, and other structural elements. The crew
consisted of 49 naval personnel and 125 civilians (NAEC-ENG-7576, 2001; Toko
Tempur Ship, 1999).
iii. United States Navy ship SIRIUS (T-AFS 8)
The USNS SIRIUS (Figure A-7), one of three ships in the SIRIUS class
operated by the Military Sea Transport Command (MSC), is a combat storage
vessel designed to provide replenishment of supplies (food, mail, ammunition,
etc.) at sea via cargo rigs and fastened helicopters. Traditionally, two H-46
helicopters are usually boarded on ships. Each ship is 524 feet long, 72 feet wide,
has a draft of 24 feet, and moves about 16,792 tons with full load. One Wallsend-
Sulzer diesel engine, and one propeller shaft were designed to propel SIRIUS-
class ships up to 19 knots producing 11520 SHP. The T-AFS 8 class ships
combine a rear flight deck that houses one helicopter during launch and recovery,
and a hangar designed to accommodate 2 folded helicopters. The flight deck is
11
It is about 63 feet long and 67 feet wide. The deck is marked and illuminated for
inclined and right harbor approaches and is 43 feet above the water level. The
USNS SIRIUS combines night lighting packages and NVDs for landings and
VERTREP. Near (just ahead) the flight deck is a very large ship superstructure.
Designed primarily to provide structural requirements for all operating rooms
above flight deck level, it also incorporates a complex array of antennas, exhaust
stacks, and other structural elements. The crew consisted of 49 naval personnel
and 115 civilians (NAEC-ENG-7576, 2001; Toko Tempur Ship, 1999).
6. DESCRIPTION OF EMPLOYABLE TECHNOLOGY AND SIMILAR H-60
TESTING EFFORTS
The field of study, i.e. the testing of helicopter-ship dynamic interfaces (and
the development of launch and recovery wind envelopes) is a relatively new field.
The complex nature of these fields (fluid dynamics, helicopter stability and
control, etc.) requires that, in order to successfully pursue and apply a full
understanding of these issues, every effort is made to use all available assets and
knowledge. Such assets and knowledge include the use of past and ongoing H-60
ship test attempts, the use of technological advances in mathematical and
aerodynamic prediction tools, and the development of helicopters designed
specifically for ship operations.

12
i. Similar H-60 Ship Test Efforts
Similar H-60 ship test efforts have been, or are underway, by various
organizations within the U.S. Navy, and by other organizations within the U.S.
Government. The most significant of the previous H-60 ship test efforts
undertaken by the U.S. Navy over the past two decades was the initial launch of
the SH-60B and SH-60F and the development of a recovery wind shield.
Although not as often as in the past during fleet introductions, launch and
recovery test attempts of the SH-60B and SH-60F continue to this day when new
ship classes emerge, as the current ship class is modified, and as ship
requirements, aircraft and mission configurations change. Previous H-60 ship test
attempts conducted by other organizations of the U.S. Government (other than the
Department of the Navy) include those conducted by the U.S. Coast Guard,
The U.S. Air Force and the U.S. Army, which all operate various versions of the
H-60, and most have been, at one time or another, conducting tests on board the
H-60.
The most significant of the current H-60 ship test efforts involving other
services is the one currently being jointly undertaken by the U.S. Army and the
U.S. Navy: the Joint Ship Helicopter Integration Program (JSHIP). JSHIP is under
the Joint Test and Evaluation Office of the Office of the Secretary of Defense.
The JSHIP Charter includes the primary objectives of developing "Army and Air
Force helicopter certification processes for operating Navy Vessels on board,"
developing "legacy processes that will account for future changes to ship and
helicopter configurations," and identifying "institutions to be accepted

13
responsibility to certify ship operations in light of these changes" (Combined Ship
Helicopter Integration Process, History, 2002). JSHIP's completed testing
includes the development of launch and recovery wind covers for the H-60A and
H-60L aboard LHA, LHD, and CVN class ships. The development of the H-60
envelope in the future is planned on board CG and FFG class ships.
ii. Mathematical and Aerodynamic Prediction Tools
One of the most qualified prediction technologies in development is
computational fluid dynamics (CFD). With the rapid growth of computing power,
it is now possible to process the tens of thousands of CFD calculations necessary
to predict a ship's aerodynamic performance under a wide range of ambient
conditions in a reasonable amount of time. With the amazing prediction tools
available, it is now possible to study a number of wind conditions on deck before
actually evaluating them on the plane. In the near future, CFD prediction
technology could enable the development of an expected launch and recovery
wind envelope that can be easily inspected or verified during limited ship tests.
Successful CFD efforts are currently underway in U.S. Navy institutions, as
are many other prediction and simulation efforts around the world (Advani and
Wilkinson, 2001; Fusato and Celi, 2001; Hess and Zeyada, 2001; Higman et al.,
2000; Wilkinson et al., 1998; Xin, Chengjian and Lee, 2001).
JSHIP also sponsors a simulation effort, the Dynamic Interface Modeling and
Simulation System (DIMSS). The DIMSS team "is developing a process using
simulations to build winds over the flight envelope of the deck and provide high-
fidelity simulations to train crews specifically for launches from and

14
recovery to air-enabled ships. To validate this process, JSHIP [has worked in
collaboration] with NASA's Ames Research Center to utilize the Vertical Motion
Simulator as a master simulator for DIMSS models and simulations" (Dynamic
Interface Modeling and Simulation Systems Overview, 2002). Due to the
tremendous success of the JSHIP DIMSS project in on-deck wind testing with
flight simulators, additional efforts have been funded by the Office of Naval
Research that will focus on modeling the ship's air build called the Ship Aircraft
Air Wake Analysis for Enhanced Dynamic Interface (SAFEDI).
iii. Early Aircraft Design
The quality of an aircraft's handling is determined primarily by its stability and
control characteristics, by the characteristics of its flight control system, and by
the pilot's workload associated with the mission or task it is expected to perform
(USNTPS FTM 107, 1995). Therefore, it is logically followed that in order to
minimize the pilot workload associated with the execution of a particular mission
or task, one must design the aircraft with stability and control and flight control
characteristics that provide optimal aircraft response (and minimal pilot workload)
during the execution of a particular mission or task.
The U.S. Army embraced this philosophy and developed a design standard, the
ADS-33D, which is now used to evaluate its latest development helicopter, the
RAH-66 Comanche. Developed by the Army, the ADS-33 is designed to evaluate
land-based helicopters and covers only ground-based missions and tasks for use in
such evaluations. Efforts to develop an ADS-33 addendum, which will address the
specific design standards required to evaluate

15
missions and duties on board (e.g. launch and recovery), are being carried out by
several interested institutions, foreign and domestic (Carignan, SJ, and A.W.
Gubbels, 1998; Carignan, S. J., A. W. Gubbels, K. Ellis, 2000; Fusato, D., and R.
Celi, 2001; Gowen, T. E. and B. Ferrier, 2001; Hess, R., and Yasser Zeyada,
2001; Higman, J., et al., 2000).
Mandatory compliance with such detailed maritime or ship design standards,
once certain maritime handling quality criteria can be precisely determined for the
specific mission and task of the vessel, is essential for the continued growth and
effectiveness of dynamic interface testing efforts. Ensuring that future helicopters,
which are expected to work safely and satisfactorily in a ship's environment,
inherently have characteristics (by design) that minimize pilot workload, is a clear
and achievable goal to pursue in an effort to improve processes designed to
maximize the operational capabilities of helicopters on board.
16
II. METHODOLOGY
1. SCOPE OF TESTING
i. Common
The test to determine the maximum operational wind-over-deck (WOD)
sheath for the MH-60S helicopter launch and recovery included shoreline and
ship-based test events, and consisted of 19 flight events and 38.7 flight hours
(32.5 day and 6.2 night hours). Beach-based testing was conducted by the Navy's
Rotary Wing Aircraft Test Squadron (NRWATS) at Naval Air Station (NAS) on
the Patuxent River, Maryland, and onboard testing was conducted by NRWATS
aboard three U.S. Navy ships off the Atlantic coast. All trial events are carried out
during the day and night, visual meteorological conditions (VMC). Detailed Test
Matrix and Test Conditions of all flight test events are presented in Table B-12.
Two MH-60S aircraft, Bureau Number (BuNo) 165742 (aircraft #1) and
BuNo 165744 (aircraft #3), were flown during this evaluation. BuNo 165742 is a
production representative of the MH-60S equipped with an advanced data
recording package that allows data telemetry and monitoring of aircraft
parameters in real time during test events. BuNo 165744 is the production
representative of the MH-60S. BuNo 165742 Basic Operating Weight (Basic
Aircraft Weight, 2 pilots, 2 crew members, and instrumentation package) is 15091
lbs. (14291
2 Tables B-1 through B-10 are located in Appendix B.
17
lbs. without a crew). BuNo 165744 Basic Operating Weight (Basic Aircraft
Weight, 2 pilots, 2 crew, and instrumentation package) is 14782 lbs. (13982 lbs.
without crew). The standard full fuel load is 2300 lbs. from the JP-5; The fuel
load is used in conjunction with the internal ballast to achieve and maintain the
desired test gross weight.
All flights are carried out in accordance with the operational parameters and
aircraft limitations outlined by the Commander, Naval Air Systems Command
(122002ZJUL00, 2000; 232006ZAUG00, 2000).3
ii. Beach-Based Handling Quality Testing
Limited coast-based handling quality testing is conducted to mitigate some of
the risks associated with ship launches and the development of recovery wind
envelopes. This test is designed to characterize the low airspeed handling qualities
of helicopters, and to allow the identification of unexpected conditions or
outcomes, in relatively benign environments.
MH-60S BuNo 165742 used for all coast-based flight tests due to the
installation of real-time data telemetry instrumentation. 1.9 flight hours were
flown during 2 coast-based test events (Events 1 and 2, Table B-1). All events
take place in the local NAS Patuxent River flying area during the day, VMC.
During all the addition of shore-based test stability, trim, and auto pilot are on, the
stabilizer is in auto mode, hydraulic pilot assist function
3 Commander, Naval Air Systems Command (COMNAVAIRSYSCOM) is the flight clearance
authority for all naval flight test flights, responsible for the definition of scope, methods and
limitations related to flight test programs, especially with respect to flight test operations outside
of the pre-approved flight envelope.
18
involved, and 3 tail rotor bias is used. The crew for all coast-based test events
consisted of two test pilots. The average test gross weight (and center of gravity)
used was 16500 lbs. (364 inches) and 21000 lbs. (355 inches).
iii. Launch and Development of Ship Recovery Wind Envelope
a) Common
The ship tests were conducted on three naval ships, representing three
different classes of ships: the United States Ship (USS) Bataan (LHD-5), the
United States Navy Ship (USNS) Concord (T-AFS 5), and the USNS SIRIUS (T-
AFS 8). The construction event (landing exercise on board) was conducted at
NAS Patuxent River, Maryland prior to the ship's testing. The onboard tests are
primarily an investigation of the quality of handling the effects of wind effects on
deck on the MH-60S helicopter during launch and recovery operations on board,
and are designed to maximize the aircraft's operational capabilities by developing
the largest possible launch and recovery wind envelope.
MH-60S BuNo 165742 and BuNo 165744 used during ship launches and
development of recovery wind envelopes. On board the first two ships (USS
BATAAN and USNS CONCORD) BuNo 165744 flown. Above the USNS
SIRIUS, due to its higher gross weight and the use of a 3 tail rotor bias, the
BuNo 165742 flown to allow real-time monitoring of aircraft parameters, i.e. tail
rotor impression pitch. In total, 36.8 flight hours (32.5 days and 6.2 nights) were
flown during 17 ship test events. Testing of the USS BATAAN resulted in a total
of 13.6 flight hours (12.1 days, 1.5 nights) and 232 launches and

19
The evolution of recovery from point 4 to 7. The USNS CONCORD test resulted
in a total of 17 flight hours (12.9 days, 4.1 nights) and 265 launch and recovery
evolutions. The USNS SIRIUS test resulted in a total of 6.2 flight hours (all day)
and 84 launch and recovery evolutions (a mechanical problem with the hangar
door necessitated an early termination of testing; only one day of the launch and
recovery period was completed).
All events take place in the U.S. Atlantic Coast Operating Area, during the
day and night, VMC. During all ship test stability augmentation systems, trims,
and autopilots are active, the stabilizer is in automatic mode, the hydraulic pilot
assist function is activated, and the tail rotor bias of 1.5 and 3 is used (for
BuNo 165744 and BuNo 165742, respectively). The crew for all ship test events
consisted of two test pilots and two crew members. The average test gross weight
and center of gravity used were 21000 lbs. and 354 inches (aboard the USS
BATAAN and USNS CONCORD), and 21750 lbs. and 355 inches (aboard the
USS SIRIUS).
In addition to following all guidelines and flight permit requirements, standard
procedures for operating in and around amphibious assault ships and air-capable
naval vessels are strictly adhered to (i.e. per NAVAIR 00-80T-106, Naval Air
Operations Training and Procedures Standardization Manual of Amphibious
Assault Ships (LHD/LHA), and NWP 3-04.1M, Helicopter Operating Procedures
for Air-Capable Vessels).
20
b) Launch and Recovery Wind Shelter Development Process
The scope of the development process of the wind envelope, launch and
recovery is crucial when new helicopters are introduced to the fleet. A basic
understanding of this scope is essential to understand the nature of launch and
recovery wind cover development and the importance of using efficient and
successful methods to develop launch and recovery wind covers.
The U.S. Navy hasn't introduced a new helicopter to the fleet for more than a
decade and, as such, has not recently had to develop a new set of launch and
recovery wind shields for operations over all classes of air-capable ships. The
investigation or evaluation required for the development of such a launch and
recovery wind envelope portfolio is a monumental effort that can span two to
three decades, which is usually the entire life of such a helicopter. In fact,
attempts to test the dynamic interface on the ship are still ongoing for both major
U.S. Navy helicopters, and the latter being introduced, the SH-60B and SH-60F,
were introduced in 1983 and 1988, respectively (SH-60B Seahawk, 2000).
The reasons for the large number of new helicopters operationally for ship
operations are numerous. The number of variables is huge and includes more than
two dozen classes of air-capable vessels, and a large number of on-deck wind
conditions, which must be tested to ensure a satisfactory and operationally
flexible wind envelope. In general, there are two categories in which factors that
contribute to

21
The magnitude of the dynamic interface problem drops. The first category
captures the factors that result in untested or modified ship air build-up and/or
helicopter aerodynamics. This category, by far, makes the greatest contribution to
the scope of such projects. This first category includes the class of ships currently
in operation and has not yet been tested, the class of ships in service that have
undergone modifications to the superstructure or deck of the ship, the class of new
ships that have entered service, the incorporation of modifications to the
helicopter fuselage, variations in the direction of approach or the location of the
landing point, and variations in wind conditions on deck during testing. The
second category captures the factors that physically limit the required period of
testing and development of the envelope. This second category includes the
availability of test aircraft, the availability of test ships and operational schedules,
as well as the conditions around the testing period. The scope of this development
process is further complicated by the theoretical, physical and mathematical
complexity of the ship's aerodynamics, the aerodynamics of the helicopter, and
their interaction with each other. However, with the advent of very powerful
computers and fields of study such as computational fluid dynamics (CFD), a
greater understanding of this complex problem is developing among the world's
governments, military, civilians and academic institutions interested in the effort.
With the institutional
collaboration results, the monumental process is the investigation of the dynamic
interface on board and the testing of new helicopters in all U classes.
The Navy's air-capable ships, S., can be a more efficient, fast, and scientific
process.
22
c) Coverage Limitations
There are some limitations in the scope of this investigation on the effects of
relative winds over deck on MH-60S during launch and recovery operations. Due
to the immaturity of the Common Cockpit avionics and flight display, and
because of the pilot's limited night experience and proficiency with this new
"glass cockpit", the development of the envelope was not carried out during the
evaluation of the first night on board (USS BATAAN). Instead, the night
evolution aboard the USS BATAAN was used to develop the pilot's night
proficiency (without the assistance of NVD) during ship operations. In addition,
to ensure the most benign environment possible during the first night ship
operation on MH-60S, the operation was carried out only within the general
launch and recovery wind cover. In addition, although the MH-60S will
eventually operate with NVD capability over all naval vessels, initial testing on
the ship is not designed to cover NVD operations; Testing all night is completely
unhelpful.
Due to time constraints imposed by the ship's operational schedule, there was
not enough time available to develop the launch and recovery wind cover for all
nine sites in the LHD. Thus, based on the points most widely used by the current
H-46D on LHD-class ships, the launch and recovery wind envelopes were
developed only for points 4, 5, 6, and 7 (see figure A-6). The development of an
expanded launch and a recovery wind envelope for the remaining places will be
carried out during future on-board tests. The restriction did not apply to single-
point T-AFS ships, and launch and recovery wind envelopes were developed for
port and starboard approaches to the ship.

23
Based on the SH-60B's high gross weight tests previously conducted by
NRWATS, there are limitations that address the maximum aircraft operating
gross weight of the MH-60S for testing. At gross weights above 21800 lbs., real-
time monitoring of the pitch of the impressed tail rotor is necessary (only possible
with the BuNo 165742 aircraft with its extensive instrumentation package). This
limit is based on the current maximum operational gross weight of the US Navy
SH-60F helicopter of 21884 lbs. During the first two periods of testing aboard the
USS BATAAN (LHD-5) and USNS CONCORD (T-AFS 5), for the sake of
building the worst conditions, and due to the fact that BuNo 165742 aircraft
(instrumented aircraft) were not available, the maximum gross weight limit of
21800 lbs. was not exceeded. In the third ship testing period aboard the USNS
SIRIUS (T-AFS 8), the necessary test equipment and personnel are available for
slightly higher gross weight testing (22250 to 21250 lbs., with a test gross weight
target of 21750 lbs.). It should be noted that during the tests, however, problems
with the hangar door on board prevented the completion of most events. A rather
limited daytime launch and recovery envelope were developed, but no night
launch and recovery or external load testing was performed.
In addition, during all test periods of launch and recovery wind envelope
development, ambient conditions (i.e. not enough ambient wind is available when
needed) and time constraints (imposed by the vessel's schedule) always hinder the
development of the launch and recovery wind envelope as much as possible. In
other words, documentation is never satisfactory
24
The quality of aircraft handling plays a major role in the definition of final launch
and recovery wind envelope. In fact, in all cases, the definition is almost entirely
due to inadequate ambient wind speed and/or insufficient time available (to
maximize the use of available winds, or to wait/seek adequate wind) to develop
the largest possible wind envelope.
Finally, due to the known reliability of the AFCS system, and based on the
limited time available for ship testing, no development of a degraded flight
control system envelope was undertaken.
2. TEST METHODS
i. Common
The U.S. Navy's rotary-wing flight test is determined by procedures and
methods standardized by and taught at the U.S. Naval Test Pilot School
(USNTPS). These methods fall under one of two main categories of flight tests,
flight test performance and handling quality, and are detailed in the following
USNTPS publications: USNTPS FTM 106, Rotor Wing Performance, United
States Navy Test Pilot School Flight Test Manual 106; and USNTPS FTM 107,
Rotor Wing Stability and Control, United States Navy Test Pilot School Flight
Test Manual
107. The flight test of the beach-based MH-60S development was carried out in
accordance with this USNTPS publication. Additional standardization of rotary-
wing flight tests, which is related to the evaluation and documentation of the
helicopter's compatibility with ships (known as dynamic interface testing (DIT)),
is

25
provided by the Naval Air Warfare Center Aircraft Division Dynamic Interface
Test Manual.
The Test Matrix and Test Conditions are provided in Table B-1, which details
the specific test events flown, the conditions encountered, and the methodology
used. A further description of the methodology is presented below.
To reduce the risks associated with developmental flight tests, a stacking
approach is used during testing. The risks associated with sequential events in the
testing process are designed to increase gradually throughout the entire testing
process, so that each test event is preceded by a more benign event, or by
practicing that event in more benign conditions than would be expected to occur
during the actual test. Thus, the day test event precedes the night test event;
Shore-based test events precede ship test events, simulated launches and ship
recovery evolutions practiced using landing points on ships painted on runways or
helicopter landing pads; and finally, prior to the launch of the ship and the
development of the recovery wind cover, the initial launch and recovery evolution
of the ship was carried out in a very limited and pre-approved General Launch
and Recovery Wind Envelope (Figures A-8 and A-9).
ii. General Quality of Handling
Aircraft handling quality is "the quality or characteristics of an aircraft that
govern the ease and precision with which the pilot can perform the tasks
necessary to support the aircraft's role" (Cooper and Harper, 1969). Some of the
factors that affect the evaluation of aircraft handling quality are stability and
control characteristics, flight control system characteristics and control laws,

26
cockpit interface (control and display), ambient conditions, and pilot workload
and stress associated with task execution. The performance of a particular flight
quality, or "the precision of control with respect to the movement of the aircraft
that the pilot can achieve in the performance of the task" (Rotary Wing Stability
and Control, 1995), is measured through the identification and use of specific
tolerances. Task performance is further measured by describing the total workload
associated with achieving tolerance parameters during task execution. The total
workload of pilots is included because the pilot's compensation for the lack of
aircraft is added to actually carrying out the task (Cooper and Harper, 1969).
The definitive work on the quantification of aircraft handling quality is "Use
of Pilot Ratings in Aircraft Handling Quality Evaluation" by G.
E. Cooper (of the National Aeronautics and Space Administration's (NASA)
Ames Research Center and R.P. Harper, Jr., (of the Cornell Aeronautical
Laboratory). In 1969, based on "objections [had] been raised to the limitations of
the scale [of the pilot rating] before," they proposed "a new definition of handling
quality, which emphasizes the importance of the factors influencing the selection
of the rating in addition to the stability and control characteristics", namely the
pilot's workload (Cooper and Harper, 1969). Their work culminated in the
development of the Cooper-Harper Handling Quality Rating Scale (HQR) (Table
B-2), a scale used, to this day, almost exclusively in the evaluation of aircraft
handling quality during specific tasks. The rating of the adequacy of the pilot to
perform certain tasks depends on the aircraft's control ability, the pilot's workload,
and whether the observed quality is satisfactory or needs to be improved (Cooper
and Harper, 1969). Designed for

27
evaluating the performance of aircraft handling quality during very specific tasks,
the Cooper-Harper HQR method was used extensively during MH-60S flight
tests, especially during the coast-based characterization of the aircraft's low-
airspeed handling qualities.
During the evaluation of the handling quality of the aircraft on board, the main
scale used was the Dynamic Interface Pilot Rating Scale (PRS), developed by the
Dynamic Interface Division of the Naval Air Warfare Center. This rating system,
presented in Table B-3, is designed to allow for the ranking of pilot workloads of
an entire evolution, or a specific set of tasks (whereas the Cooper-Harper HQR
Scale is designed to allow for the ranking of pilot workloads over a single, very
specific task). For example, the PRS Dynamic Interface is used to evaluate the
entire evolution of ship recovery, which consists of many individual tasks, each of
which occurs in sequence: initial takeoff to hover; maintenance of altitude and
direction when hovering; transition from the ship's deck to advanced flight and
altitude maintenance; heading and tracking on the ground; climbing to the height
of the pattern; and maintenance of pattern altitude and airspeed. Similarly, the
PRS is used to evaluate the entire evolution of the launch, which is also made up
of many individual tasks, each of which occurs in sequence: a descending turn for
the deck of a ship lined up from the height of the pattern; maintenance of aircraft
direction, airspeed, glide slope and trajectory above ground on the final approach;
transition to hover over deck; maintenance of altitude and direction when
hovering; and descended to the deck of the ship to land.

28
The Dynamic Interface Pilot Rating Scale incorporates the outstanding
principles of Cooper and Harper, which are modified to accommodate the
uniqueness inherent in the evaluation of aircraft handling quality on board. Pilot
effort and workload are still the primary focus of rating determination, and the
importance of safe repeatability and aircraft controllability is still important. In
addition, pilot workload ratings also typically take into account parameters such
as remaining control margins, torque management, WOD speed and direction,
ship movement, and field of view (FOV) (Dynamic Interface Test Manual, 1998).
Over the course of hundreds of launch and recovery evolutions over an ongoing
period, PRS provides practicality and usefulness, prevents excessive
quantification of aircraft handling quality data, and enables efficient capture of
sufficient data for wind investigation and envelope development.
The other three rating scales were used during the evaluation of the handling
quality of the MH-60S to facilitate the description of the various qualitative
phenomena observed during the tests. This phenomenon has been considered
quite important to have their own rating scale because the presence of any or all of
them can result in an increase in pilot workload and a higher overall pilot rating.
The Vibration Rating Scale (VAR) (Table B-4) is used to describe the
observed or significant vibrations. The Pilot Induced Oscillation (PIO) Rating
Scale (Table B-5) is used to facilitate the classification of aircraft vulnerability to
PIO during duty. The Turbulence Rating Scale (TURB) (Table B-6) is used to
help

29
describing turbulent environmental conditions during the performance of duties.
VAR, PIO ratings and TURB ratings are established using USNTPS guidelines
(USNTPS FTM 107, 1995).
iii. Beach-Based Handling Quality
In the interest of mitigating the risks associated with ship launches and the
development of recovery wind envelopes, controlled coast-based studies on
handling qualities and aircraft characteristics in low airspeed regimes were
included in the testing process. The study is designed to initiate the
characterization of the handling quality of helicopters at low airspeeds, to allow
for the identification of conditions or unexpected outcomes in relatively benign
environments, and to provide some insight into the performance of the handling
quality expected during the operation of low-airspeed vessels. Specifically, low
airspeed flight tests are conducted to determine aircraft control margins and
evaluate aircraft handling quality during operations in crosswind, backwind, and
gale conditions. The results allow the test team to estimate, or roughly predict, the
quality of the aircraft's handling in a similar regime while on board, as well as
identify combinations of azimuth and wind speed that may result in
unsatisfactory, and potentially dangerous, handling quality. This helps minimize
the amount of unexpected handling qualities found during ship testing, and allows
the test team to build the largest launch and recovery wind envelope in the safest
way possible, while avoiding or very carefully approaching these so-called
"critical azimuths".

30
During the coast-based low airspeed test, the aircraft's handling quality was
documented with the relative winds of several different speeds, from several
azimuth around the helicopter. Specifically, airspeed varies from 0 to 45 knots
true airspeed (KTAS) in increments of about 10 KTAS, and azimuth varies across
the 360 range in increments of 30 or 45.
The MH-60S helicopter is equipped with a conventional pitot-static system to
determine the indicated airspeed. Such a system cannot accurately determine the
airspeed of less than 40 KIAS. In addition, due to the fact that the pitot-static ports
are aligned for forward flight, such a system is also unable to accurately
determine the indicated airspeed when the relative wind is not coming from
directly in front of the aircraft. Due to the limitations of the pitot-static airspeed
system in a low-airspeed environment, the speed truck, which is equipped with
low-airspeed detection capability, is used during testing to aid in the
determination of the actual airspeed. When targeting azimuths, the speed truck
system calculates the required ground speed (based on the available runway
direction and ambient winds) to obtain the various target wind conditions (actual
air velocity) for each targeted azimuth. The helicopter was then flown down the
runway used, in formation with trucks, at a constant altitude. The helicopter's
direction varies as needed to accommodate the limitations imposed by the use of
the runway with each running data (and rarely does the aircraft head to coincide
with the above-ground path). Once set at a stable airspeed, the flight control
position, required torque, and aircraft attitude are recorded. In addition, pilot
ratings (HQR, VAR, TURB scales) are assigned, if necessary, for each data point.
Desirable and adequate
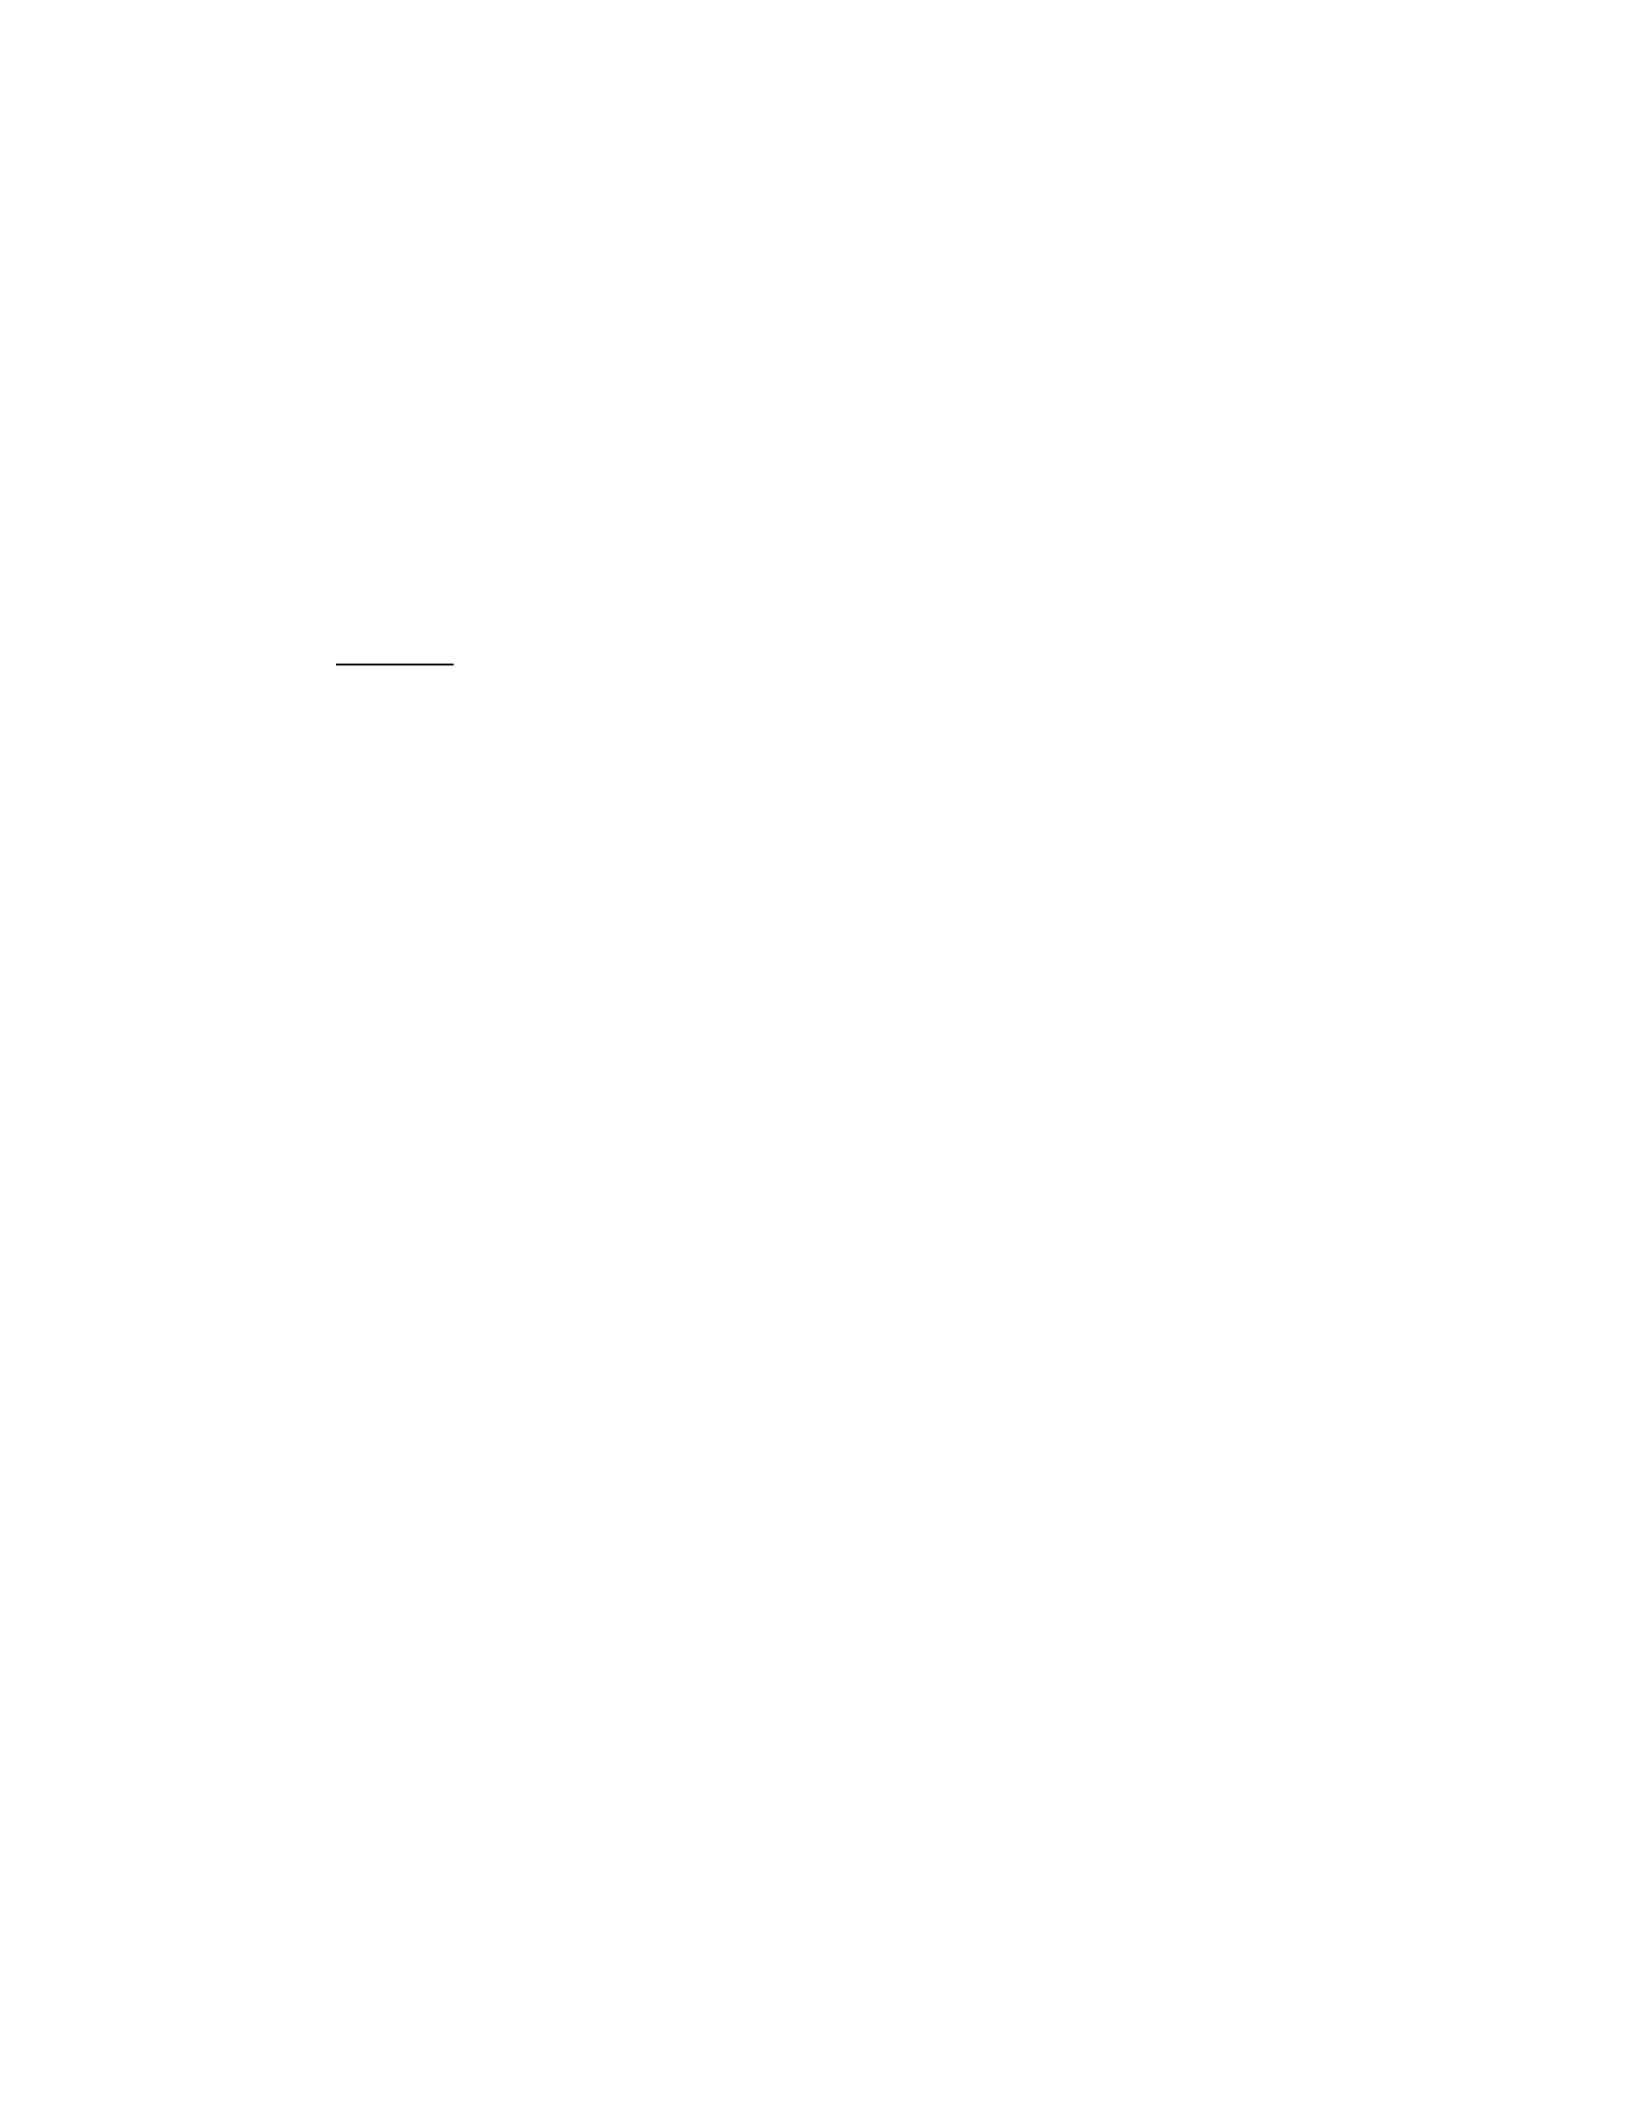
31
The tolerances used for HQR assignment are 3 5 , 3
5 direction, and 1 2 , . and KTAS airspeed respectively The test was
carried out on two different gross weights to determine the effect of gross weight
on the handling quality of the aircraft (USNTPS FTM 107, 1995).
iv. Ship Handling Quality
a) Common
Testing of the ship's dynamic interface is carried out to evaluate and develop
all aspects of the ship's helicopter compatibility. Such tests almost exclusively
consist of examining the quality of handling the effects of ambient winds and the
resulting ship air build-up (or relative wind above deck) on helicopters during
launch and recovery operations. The main goal of the test is to maximize the
operational flexibility of the helicopter in the ship's environment through the
development of launch and recovery wind envelopes on board.
A special investigation into the effects of wind on deck winds on the ship's
helicopter operations was carried out to develop a maximum above-deck wind
launch and recovery envelope for MH-60S helicopters aboard WASP-class
amphibious assault ships (LHD-1), and MARS-class (T-AFS 1) and SIRIUS (T-
AFS 8) class combat ships.
This test is designed to result in an extension of the general launch and
recovery wind envelope (Figures A-8 and A-9) that have been approved (by
COMNAVAIRSYSCOM) for use by MH-60S in all U.S. classes.
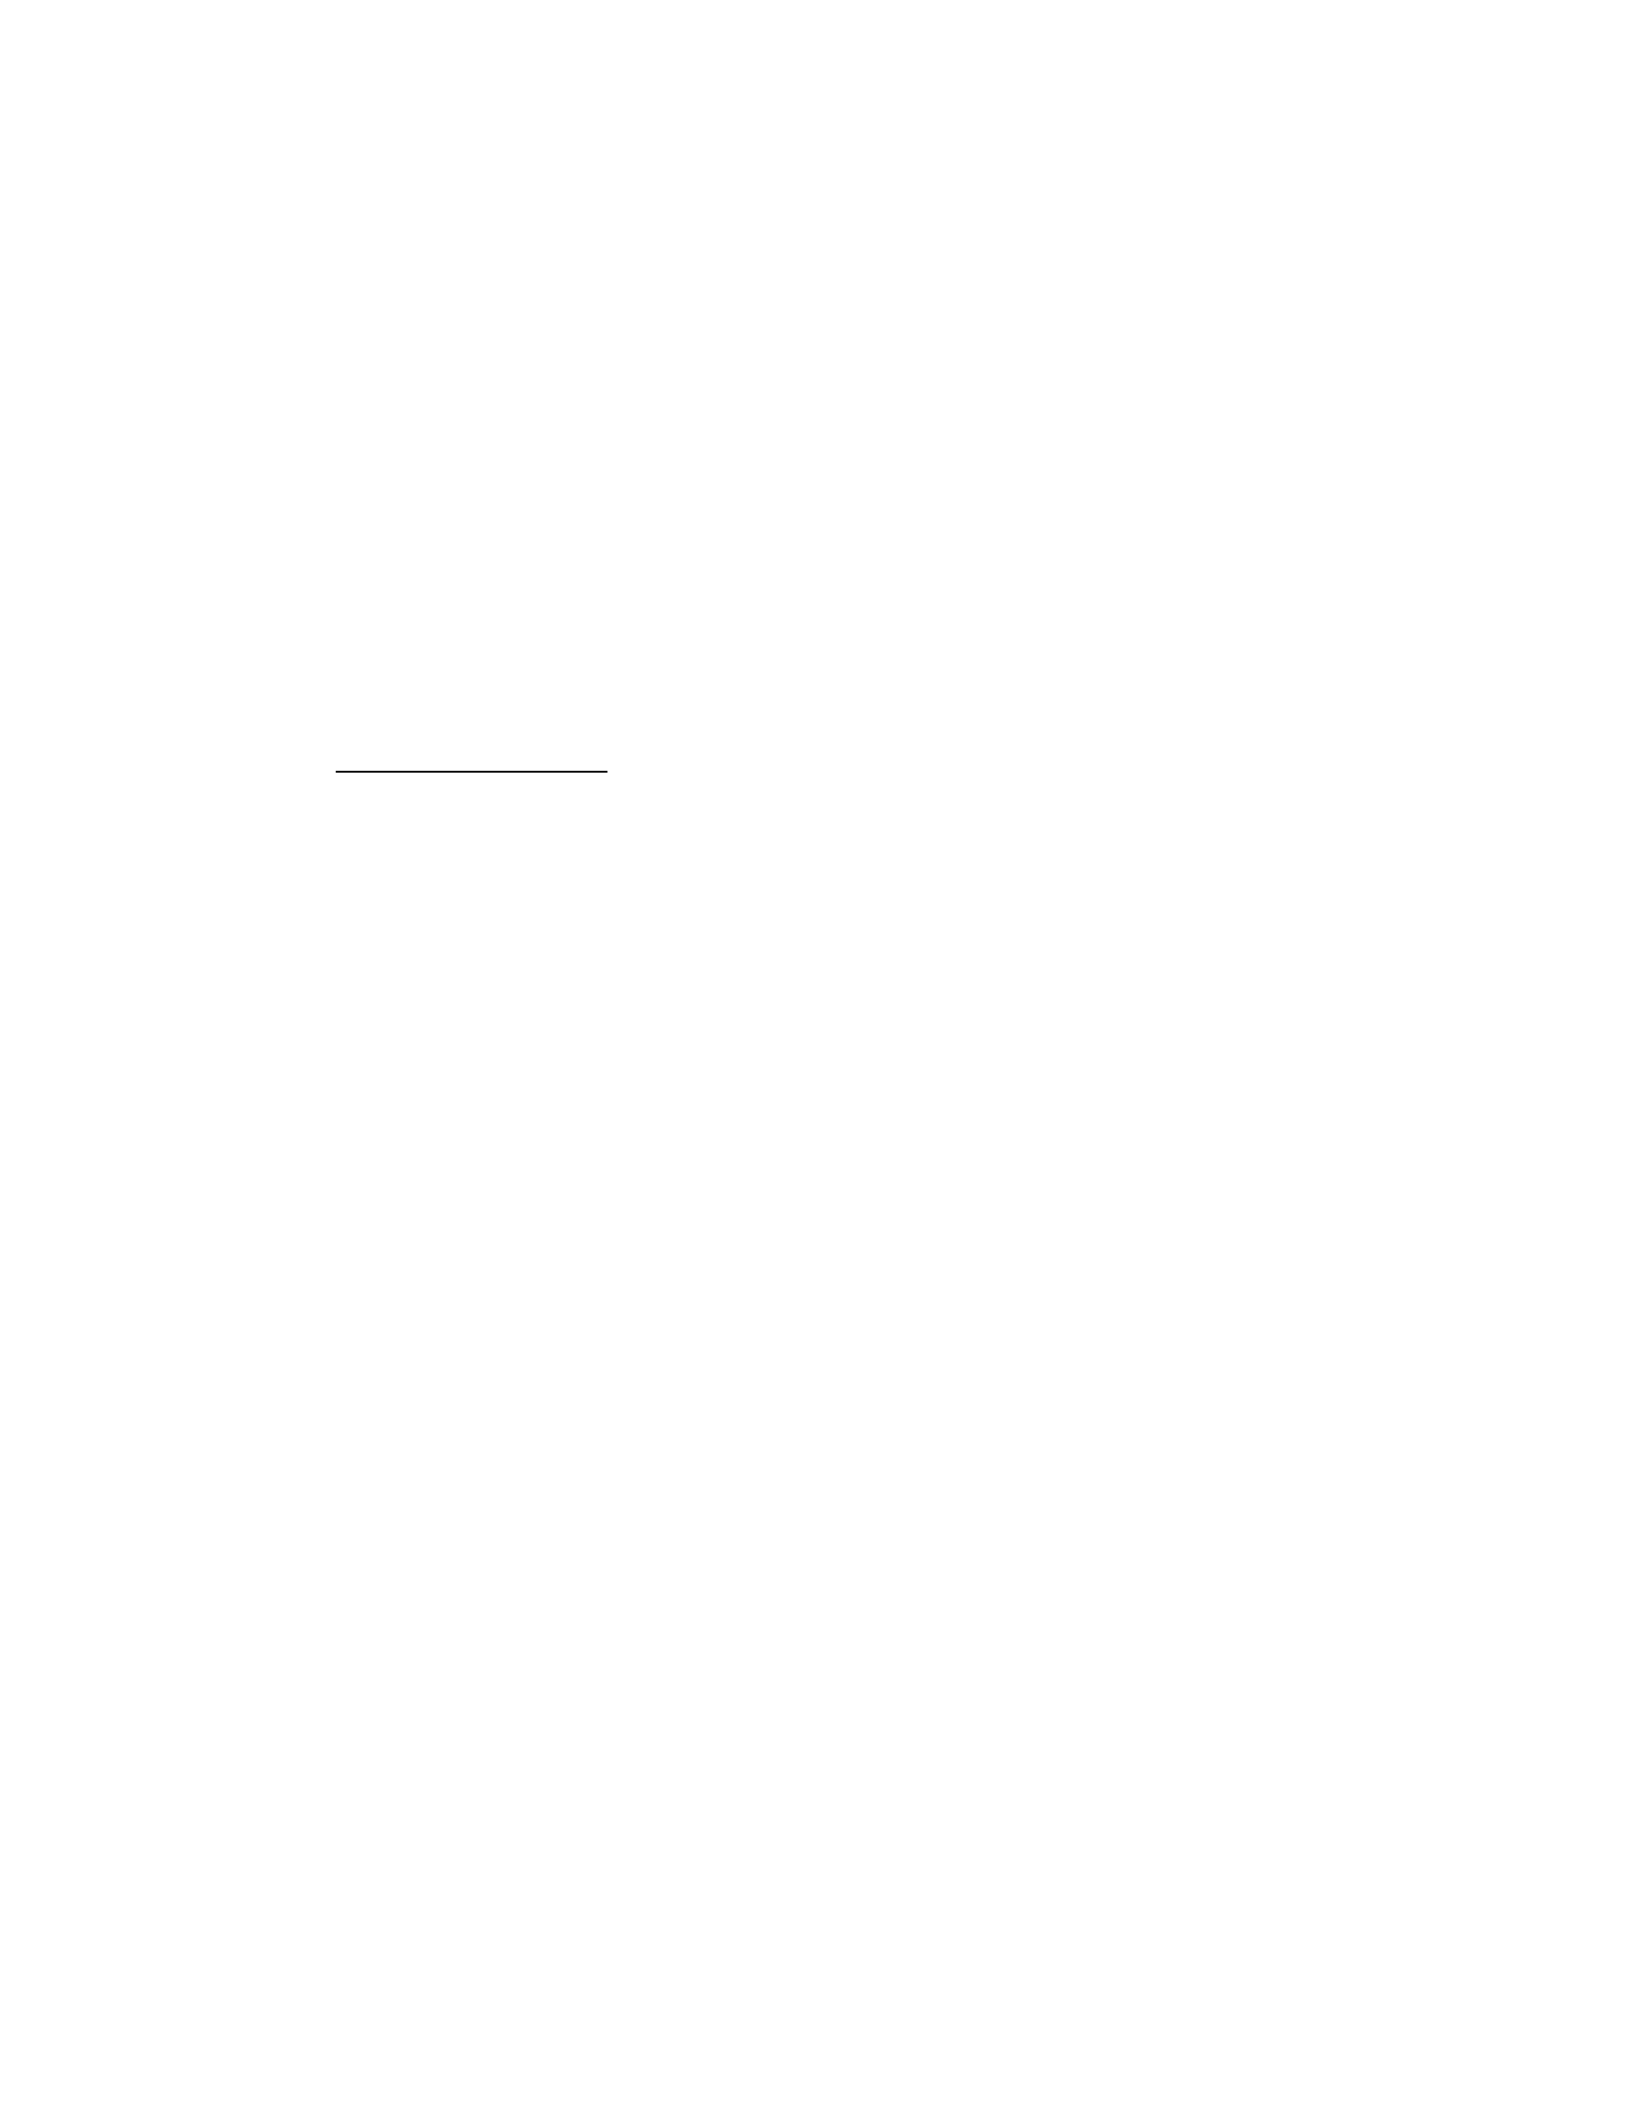
32
Navy ships. This common envelope is, by design, very limited and allows for
launch and recovery only in very benign conditions. They are designed to be used
by U.S. Navy helicopters aboard any U.S. Navy ship allowed to land, if an
extended launch and certain recovery wind shields are not present. Typically, this
general launch and recovery wind shield only applies when a new helicopter or
new ship enters fleet service, or if the helicopter must land on top of a type of ship
that does not normally land on board.
b) Ship Landing Pattern
The landing pattern on the ship is specifically designed for, or adapted to, each
class of air-capable vessel. They allow the management of a safe airspace around
such a ship during the launch and recovery of the aircraft to and from the deck of
its ship.
Operations to landing points 4, 5, 6 and 7 aboard LHD-1 class ships required
an approach from the port side of the ship. This is created using the 45 line up
associated with the landing site being tested (see Figure A-10), and the pilot is in
control during each approach is always the closest to the superstructure (i.e. the
approach to the port point is flown by the pilot in the right seat). The evolution of
the day recovery consisted of: a 3 glide slope interception at 300 feet AGL and
1/2 mile (at 70 KIAS) on the port side of the ship, a straight approach up the line
to the spot, a left pedal turn to align the aircraft with the ship's direction while
switching to hovering 10 feet above the landing site, and a vertical landing on the
ship's deck. The landing of the ship's deck is carried out in numbered places in

33
direction of the ship, with the main mount wheel on the line of athwartships. The
evolution of day launch consists of: vertical takeoff to hover 10 feet above the
landing site, lateral movement left from deck and exit over the water, and
simultaneous transition to forward flight (300 feet and 70 KIAS). The launch was
flown by the same pilot who performed the recovery and departure was flown in
the direction of the ship. Between the evolution of launch and recovery, the
harbor-side, left-hand racetrack pattern was flown at 300 feet AGL and 70 KIAS.
The night launch and recovery procedures were flown using exactly the same
procedures.
Operations to ships of the T-AFS class at one point can be carried out using
approaches from the port or the starboard side of the ship. This is created using
one of the ship's deck lines (port-to-starboard or right-to-port) as a reference for
the final line up (see Figure A-11), and the pilot is in control during each
approach is always the closest to the superstructure (i.e. the port-to-right approach
is flown by the pilot in the left seat, and the right-to-port approach is flown by the
pilot in the right seat). The evolution of day recovery consisted of: a 3 glide
slope interception at 150 feet AGL and 1/2 mile (at 70 KIAS), a straight approach
up the line to the spot, a transition to a hover 10 feet above the deck landing area,
and a vertical landing on the deck of the ship. The deck landing was carried out on
the line up referenced during the approach, with the main mount wheels landing at
the front of the nose wheel circle. The evolution of day launches consists of:
vertical takeoff to hover 10 feet above the landing area of the ship's deck, pedal
rotation
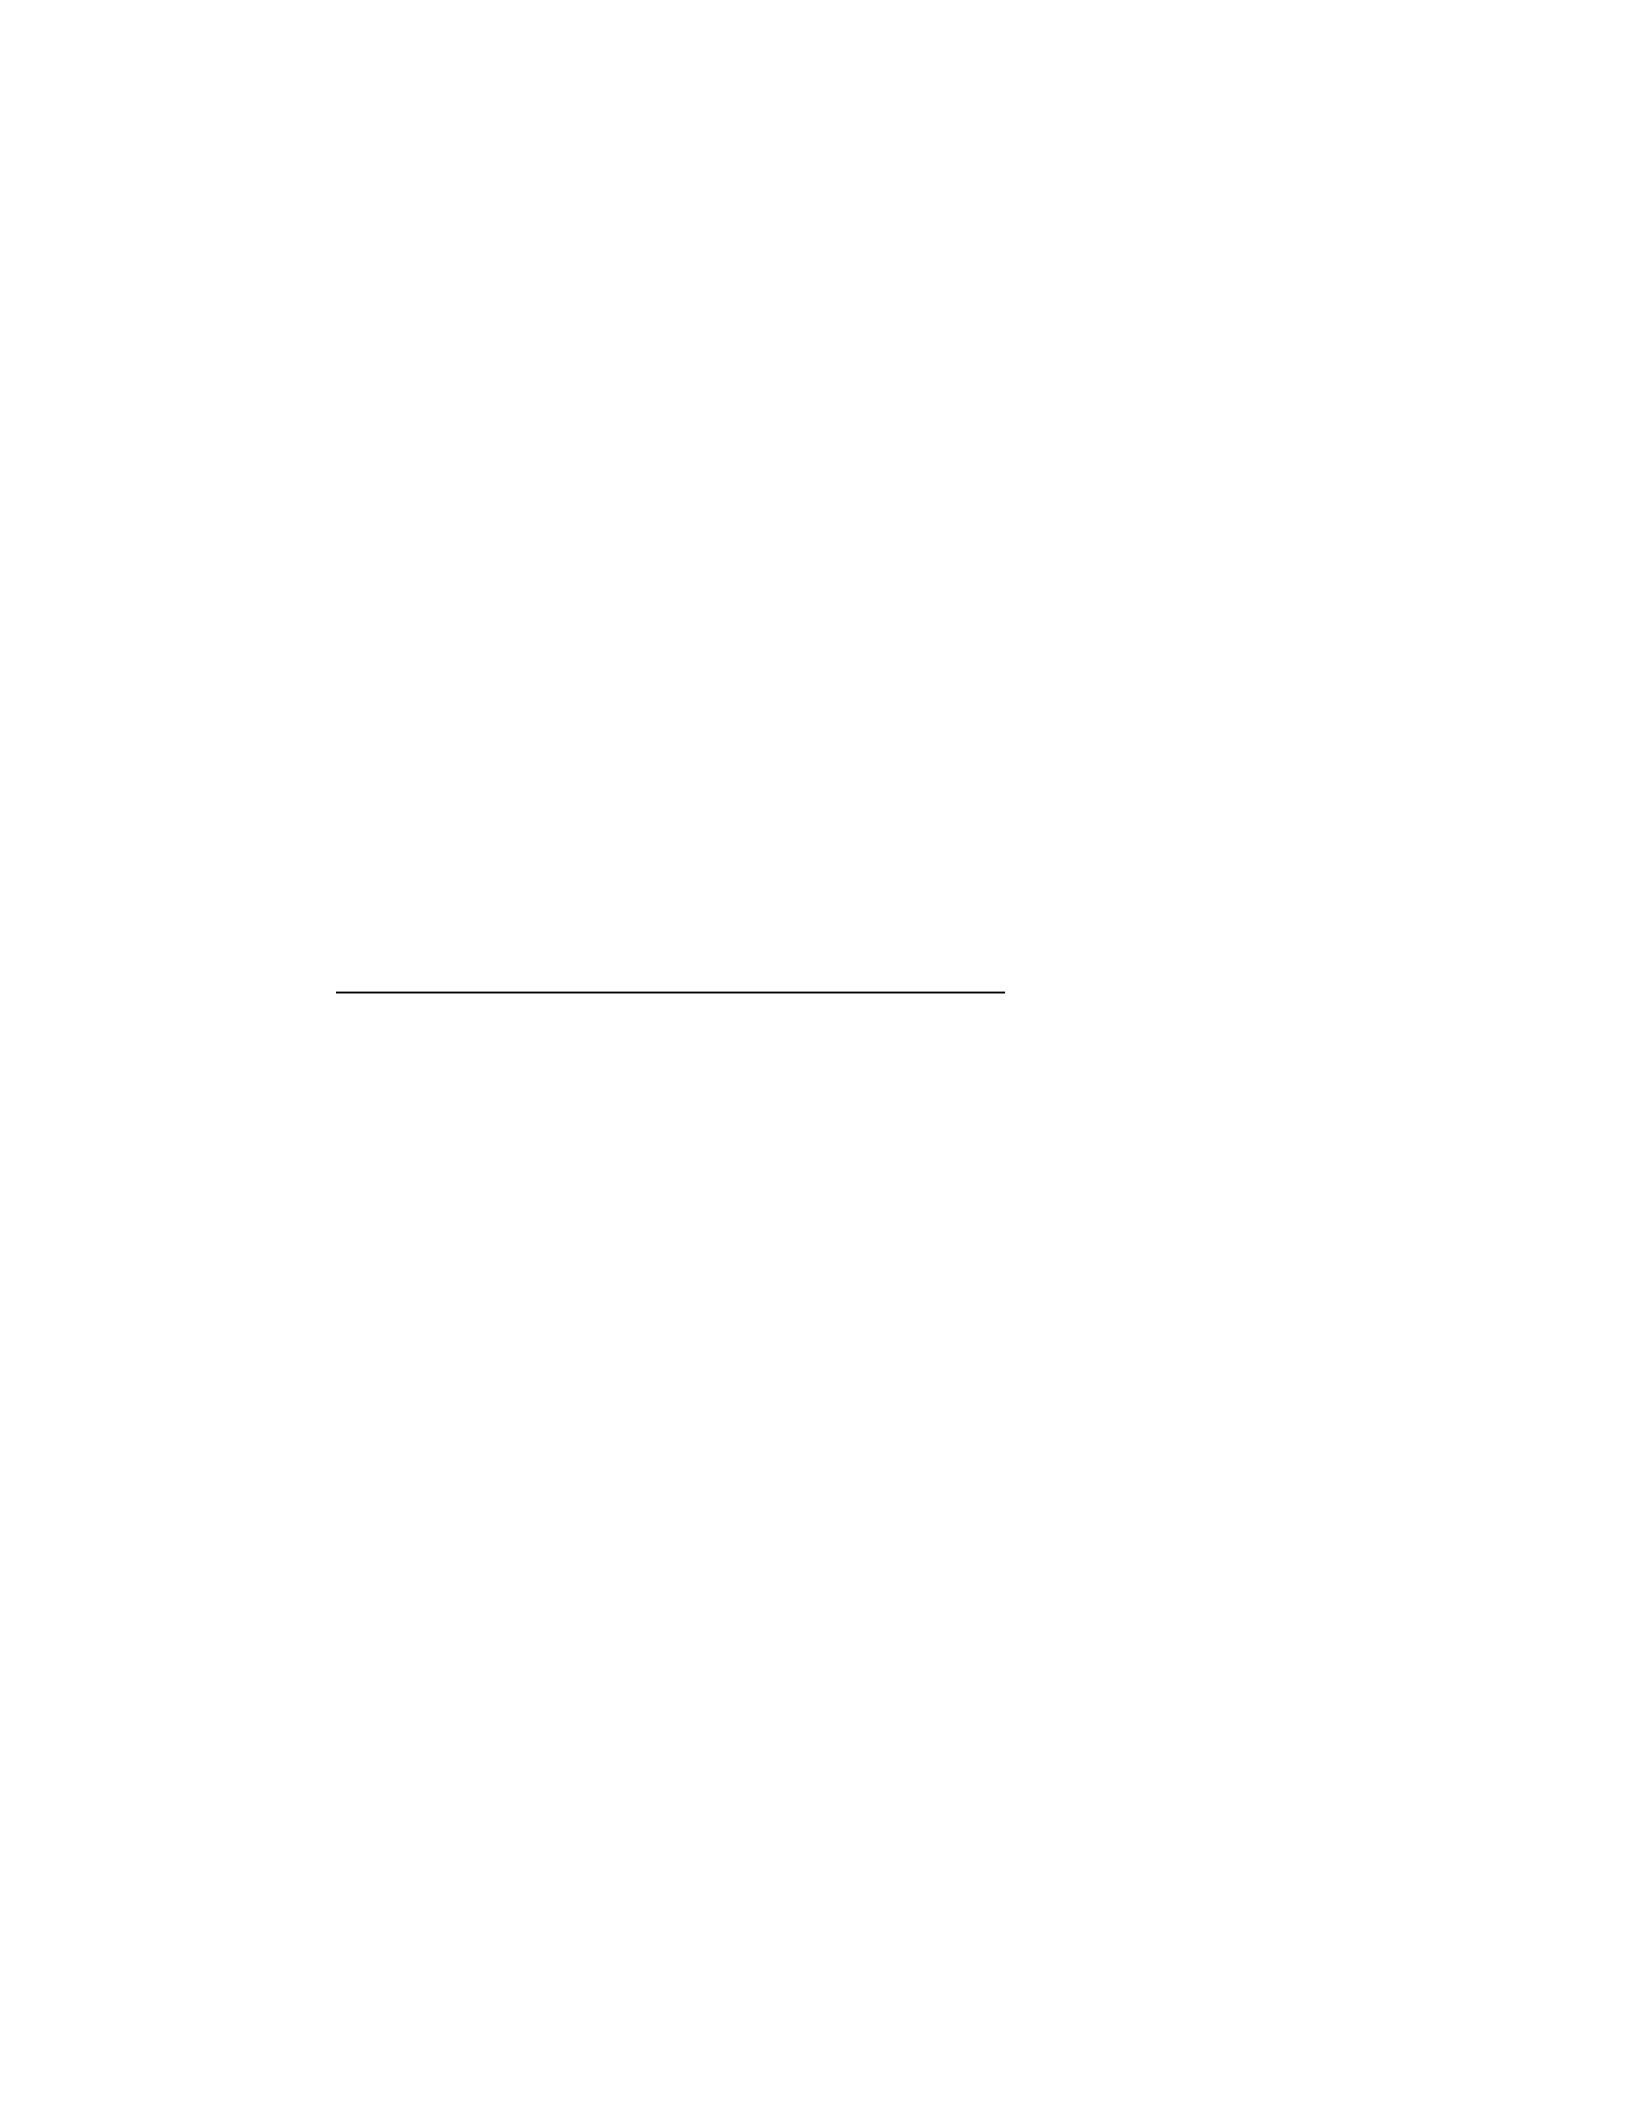
34
left or right in the direction of the planned departure about 45 from the direction
of the ship, and transition to forward flight (150 feet AGL and 70 KIAS). The
launch was flown by the same pilot performing the recovery, and the general
direction of departure was the same as the recovery (i.e. the departure to the right
was flown after the port to the right approached, and the departure to the port was
flown after the right to the port approached). Between the evolution of launch and
recovery, the pattern of port racing tracks, left or right, right is flown at 150 feet
AGL and 70 KIAS. The night launch and recovery procedures were flown using
exactly the same procedure with the exception of the pattern altitude, which was
300 feet AGL.
c) Wind Envelope Development Launch and Recovery
The development of the launch and recovery envelope entails the expansion of
the general launch and recovery envelope previously authorized for LHD and T-
AFS class vessels. The initial above-deck wind conditions (WOD) (velocity and
azimuth) to be tested are located within the prevailing general launch and
recovery wind envelope (LHD or T-AFS). One wind azimuth at a time is
investigated, and the wind speed varies while maintaining a constant wind
azimuth. Once the maximum wind speed is reached for a given wind azimuth,
either due to the limitations of the surrounding wind or the assignment of an
unacceptable handling quality rating, the wind azimuth is then varied. In setting
the WOD conditions for sequential test points, the conditions vary by a maximum
of 5 knots of speed or 15 direction. For each relative WOD condition, at least
one launch and one recovery evolution is attempted, and a PRS rating is assigned

35
(one for the entire launch evolution, and one for the entire evolution of recovery).
If a satisfactory PRS rating (PRS-1 or 2) is assigned for the evolution of launch
and recovery, under certain WOD conditions, the ship is maneuvered to achieve
the required WOD conditions for the next test point. The initial WOD conditions
for each successive ship flight test period are located within the boundaries of the
previously tested envelope. Occasionally, the condition of a WOD is retested to
provide a rating validation check of the PRS rating previously assigned to that
condition, provided the PRS rating is satisfactory (PRS-1 or 2).
PRS ratings and related aircraft handling quality comments are submitted to
test engineers on board either in flight or on deck, upon completion of the
evolution. If the PRS-3 rating is assigned to evolution, that evolution, under the
same WOD conditions, can be repeated for verification, with the approval of the
crew and the test team. After the establishment of such a rating, the wind speed is
reduced by an increase of 5 knots, while maintaining a constant wind azimuth,
until a satisfactory PRS rating is reached. If PRS-4's rank is set for evolution, the
WOD condition will then be reduced to a level corresponding to the previous
PRS-1 or 2 rank, before performing another evolution. (Dynamic Interface Test
Manual, 1998).
During the night launch and the development of the recovery wind envelope
(carried out only on board the T-AFS-class ships) exactly the same test methods
were used, except that the night general launch and recovery envelope were used
as the starting point. No night launch and recovery wind envelope development
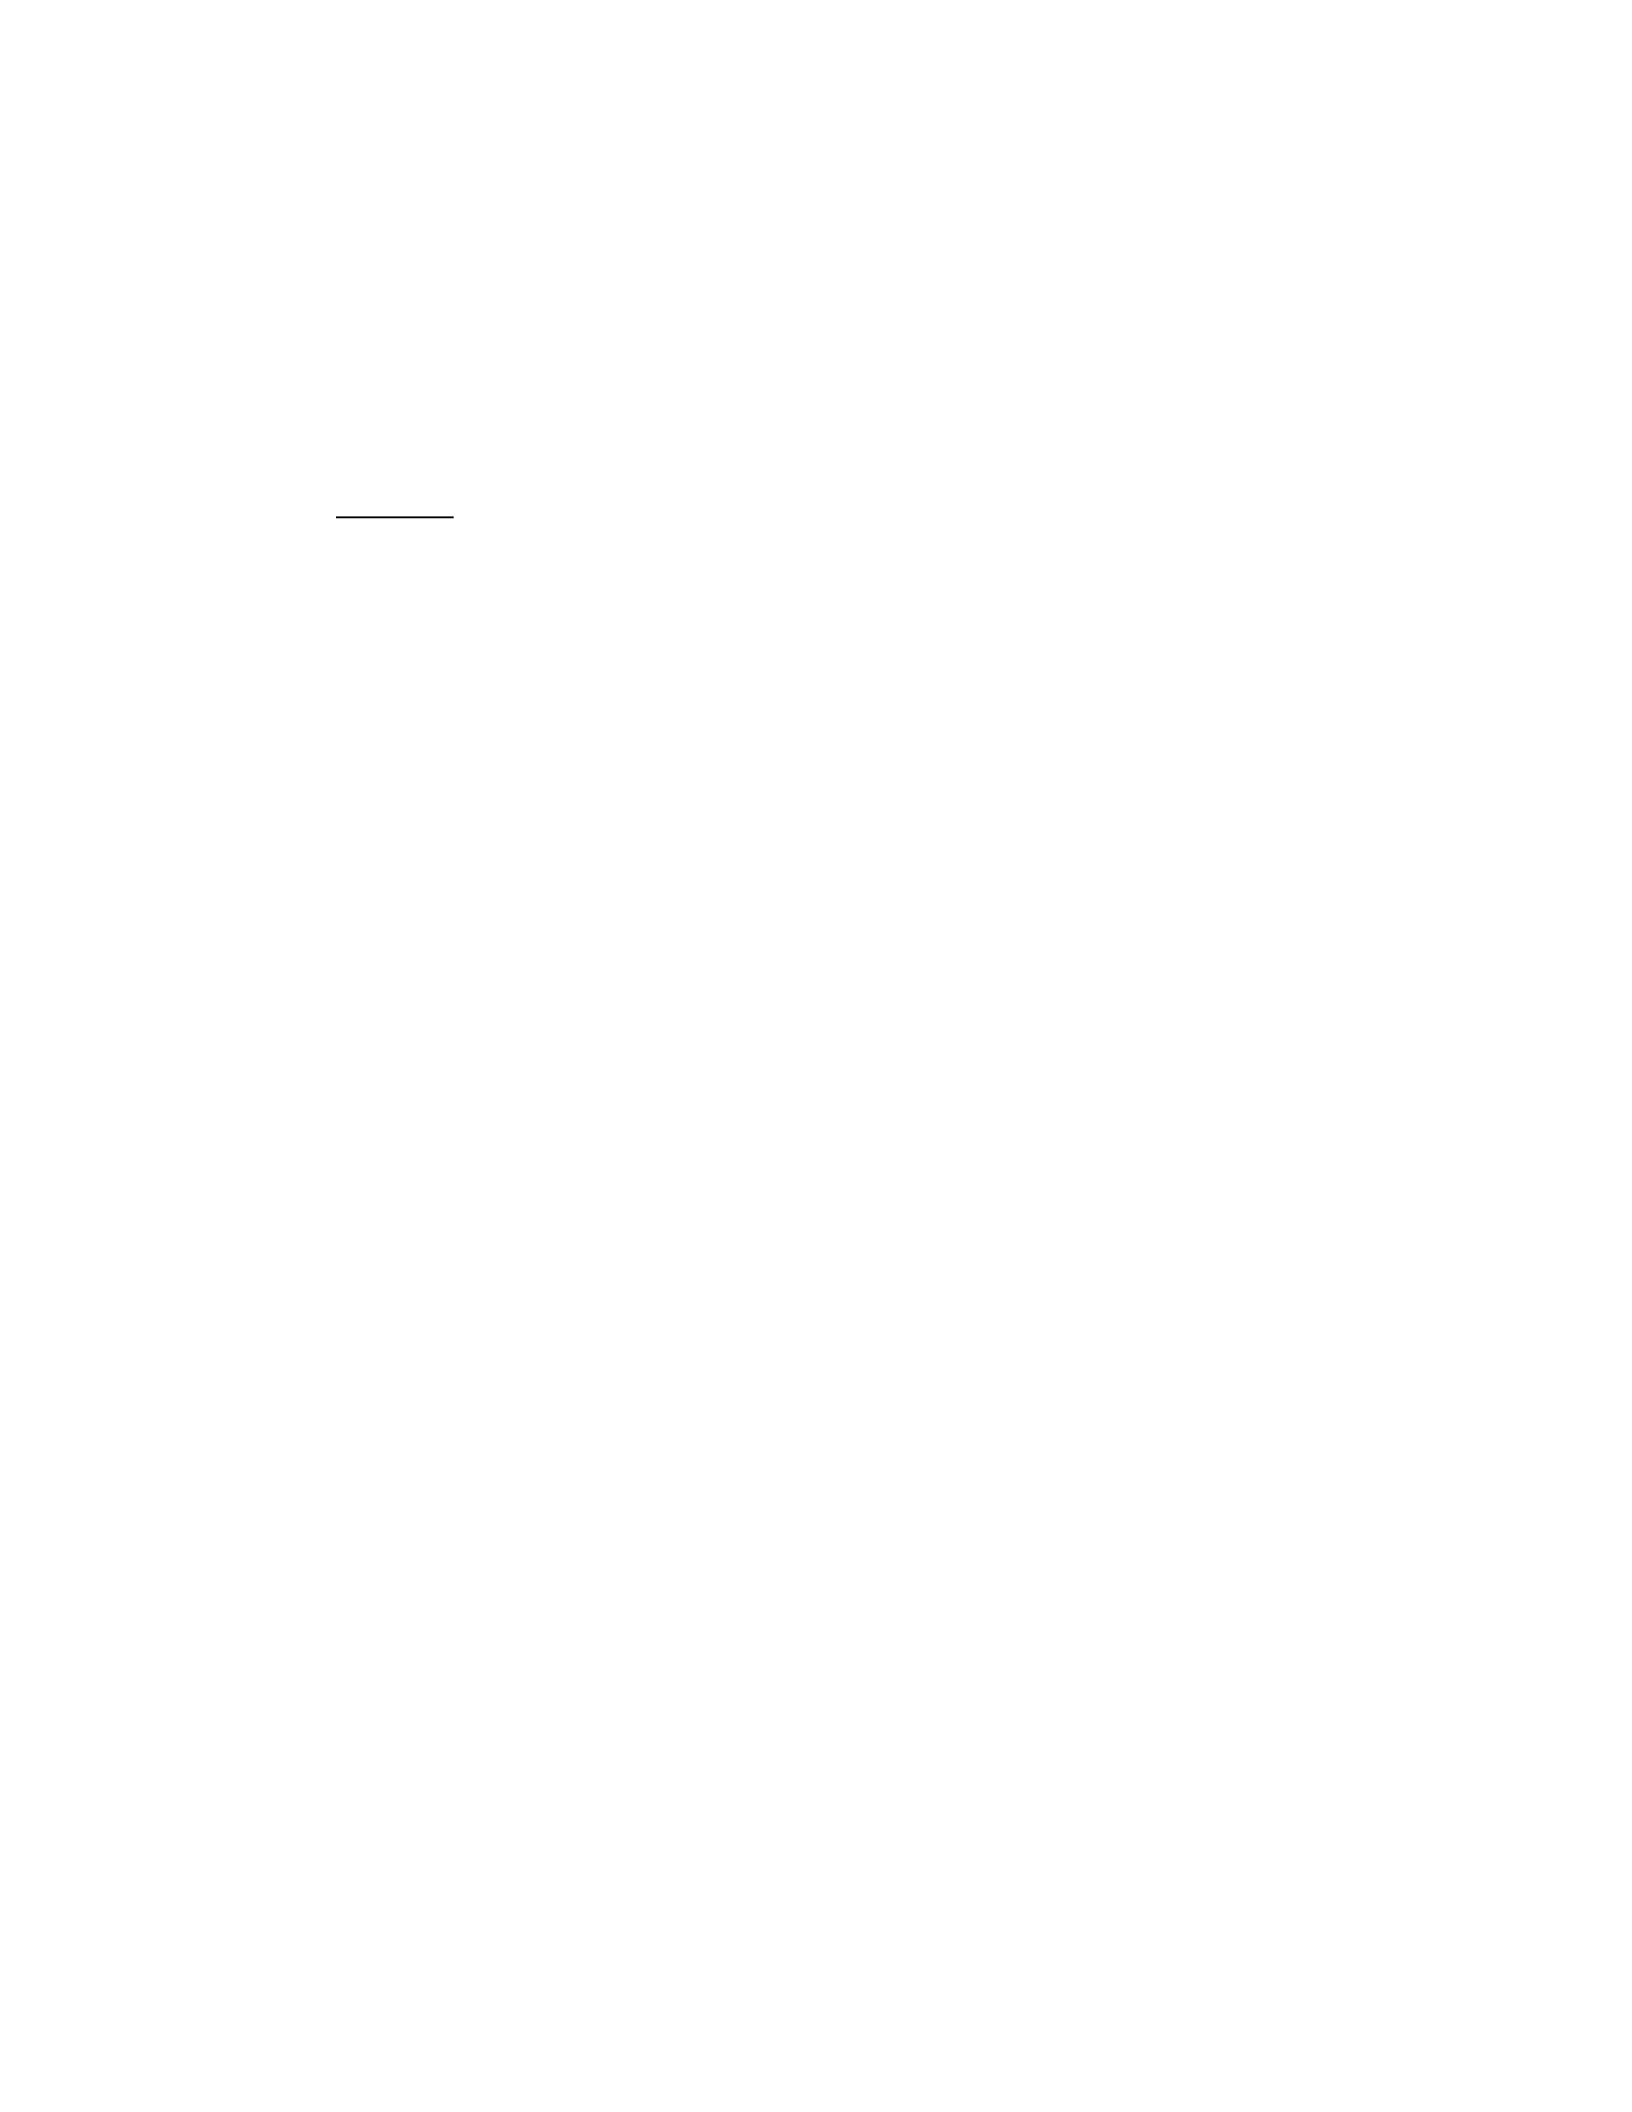
36
carried out aboard the USS Bataan (LHD-5). Conditions throughout the previous
night were evaluated during daytime testing.
v. Aircraft Data Collection and Instrumentation
a) Common
The beach-based handling quality testing related to this investigation is only a
small part of the considerable development of aerial vehicle testing efforts
undertaken to evaluate the MH-60S helicopter's performance and handling
quality. Due to the breadth of testing of these aerial vehicles, and the importance
of testing with respect to the program's production milestones, a very complex
real-time data collection package (via telemetry) was included on the first
airframe received by the US Navy (BuNo 165742). Thus, although manual data
entry on the kneeboard card is the primary means of recording data (basic
parameters of the aircraft, pilot ratings, ambient conditions) during the two coast-
based testing events pertaining to this thesis, additional quantitative data is also
available.
During the launch of the ship and the development of the recovery wind
sheath, when the maximum gross weight of the aircraft is at or below 21800 lbs.,
data (i.e. pilot rating, basic aircraft performance parameters, ambient conditions,
and ship movement) are manually recorded on the kneeboard data card. The
displacement of the control position is estimated, if necessary.
Testing above 21800 lbs. gross weight is only permitted on instrumented
aircraft, and only when real-time data monitoring of critical parameters is used.
Critical parameters during high gross weight testing

37
(above 21800 lbs.) including the pressure and strain of the fuselage and dynamic
components, the vibration level of the aircraft, and, most importantly, the pitch of
the tail rotor impression. Because the pitch (or authority) that the impression of
the remaining tail rotor is directly related to the gross weight of the aircraft
(through the collective due to the mixing of controls into the tail rotor), and
because the U.S. Navy has never operated an H-60 with a gross weight of more
than 21800 lbs., this real-time monitoring of data is considered a requirement.
Furthermore, the incorporation of 3 1.5 vice tail rotor bias traditionally used
by U.
S. Navy (resulting in more left pedal authority for operation at higher gross
weights), warranting the use of detailed data collection to validate the usefulness
and/or necessity of such incorporation.
Real-time monitoring of telemetry data during high-risk test events (i.e. high
gross weight operations) ensures that critical parameters are over-monitored by
test engineers in a benign environment, in the case of parameters that can also be
monitored by the pilot during testing. In addition, data telemetry gives test teams
the opportunity to monitor critical parameters in real-time that are not typically
presented to pilots. In all cases, data telemetry, and its real-time monitoring, gives
a number of test team members the opportunity to terminate high-risk test
conditions, immediately, and before the development of unsafe flight conditions.
In the interest of ongoing risk mitigation, the gross weight of the aircraft
during the first ship test period (above the USS BATAAN and USNS
CONCORD) was not designed to exceed 21800 lbs. Thus, instrumented aircraft
are not required or used. However, aboard the USNS SIRIUS, the test is designed
38
to evaluating the handling quality of aircraft at gross weights of more than 21800
lbs., and BuNo 165742 aircraft, with real-time data monitoring, is required.
During shore and ship-based testing, data collection is facilitated by
communication with land-based test engineers.
The data collected are reduced and presented as outlined in the USNTPS
Flight Test Manual (USNTPS FTM 106 and FTM 107). The dynamic interface
test data is displayed graphically using the Naval Air Warfare Aircraft Division
software program specially designed by the Dynamic Interface Test Branch to
provide a graphical presentation of the ship's wind envelope test data.
b) Aircraft Bureau Number 165742 Data Collection Package
To collect detailed air vehicle flight test data, an extensive data collection
package is installed on the BuNo 165742 aircraft. The package is designed to
record hundreds of parameters onto digital tape, and uses a high-speed pulse code
modulated format (PCM). In addition, the package is designed to provide real-
time monitoring of ground-based aircraft parameters during test events. Specific
parameters of interest for telemetry and recording during the testing of aerial
vehicles and dynamic interfaces are: turbine engine power and gas generator
speed, engine temperature and torque, rotor speed, fuel amount, calibrated and
indicated air speed, pressure altitude and radar, climb rate, flight control position,
tail rotor impression pitch, heading, pitch and roll attitude, pitch, roll and yaw
rate, sideslip, and EGI speed (3 axes). A complete list of instrumented parameters
is presented in Table B-7.
39
III. RESULT
1. COMMON
The results of the investigation of the effects of the relative wind above deck
on the MH-60S helicopter during the launch and development of the recovery
wind envelope were presented in four different discussions. The former presents
the results of a coast-based handling quality investigation conducted in an effort
to better understand the characteristics of qualitative aircraft handling in often
unpredictable low-airspeed environments, and before investigating them in more
unpredictable low-airspeed ship environments. The second discussion presented
the results of ship launches and the development of recovery wind envelopes and
investigations related to the effects of wind on deck on the quality of aircraft
handling in the ship environment. A third discussion was presented that discussed
documented pilot-vehicle interface deficiencies that were identified as negatively
contributing to the pilot workload required during the ship's launch and recovery
operations. Finally, a discussion was presented relating to the process used by the
US Navy in the development of the first MH-60S wind launch and recovery.
Although the evaluation of the launch and recovery wind envelope development
process was not specifically identified as the goal of this investigation, this author
feels that some shortcomings in this process are significant and, in order to
improve the sustainable development of the MH-60S wind jacket, are worth
documenting and discussing.
40
2. BEACH-BASED HANDLING QUALITY
During the evaluation of the quality of coast-based handling, which was
conducted in a relatively benign coast-based environment, various conditions of
drifting winds (cross, tail and gale) were simulated using speed paths and low
airspeed calculation systems. Relative winds of 10, 20, 30, 40, and 45 knots of
true airspeed (KTAS) were evaluated while varying the relative wind azimuth in
30 increments around the entire 360 range (relative to the nose of the aircraft).
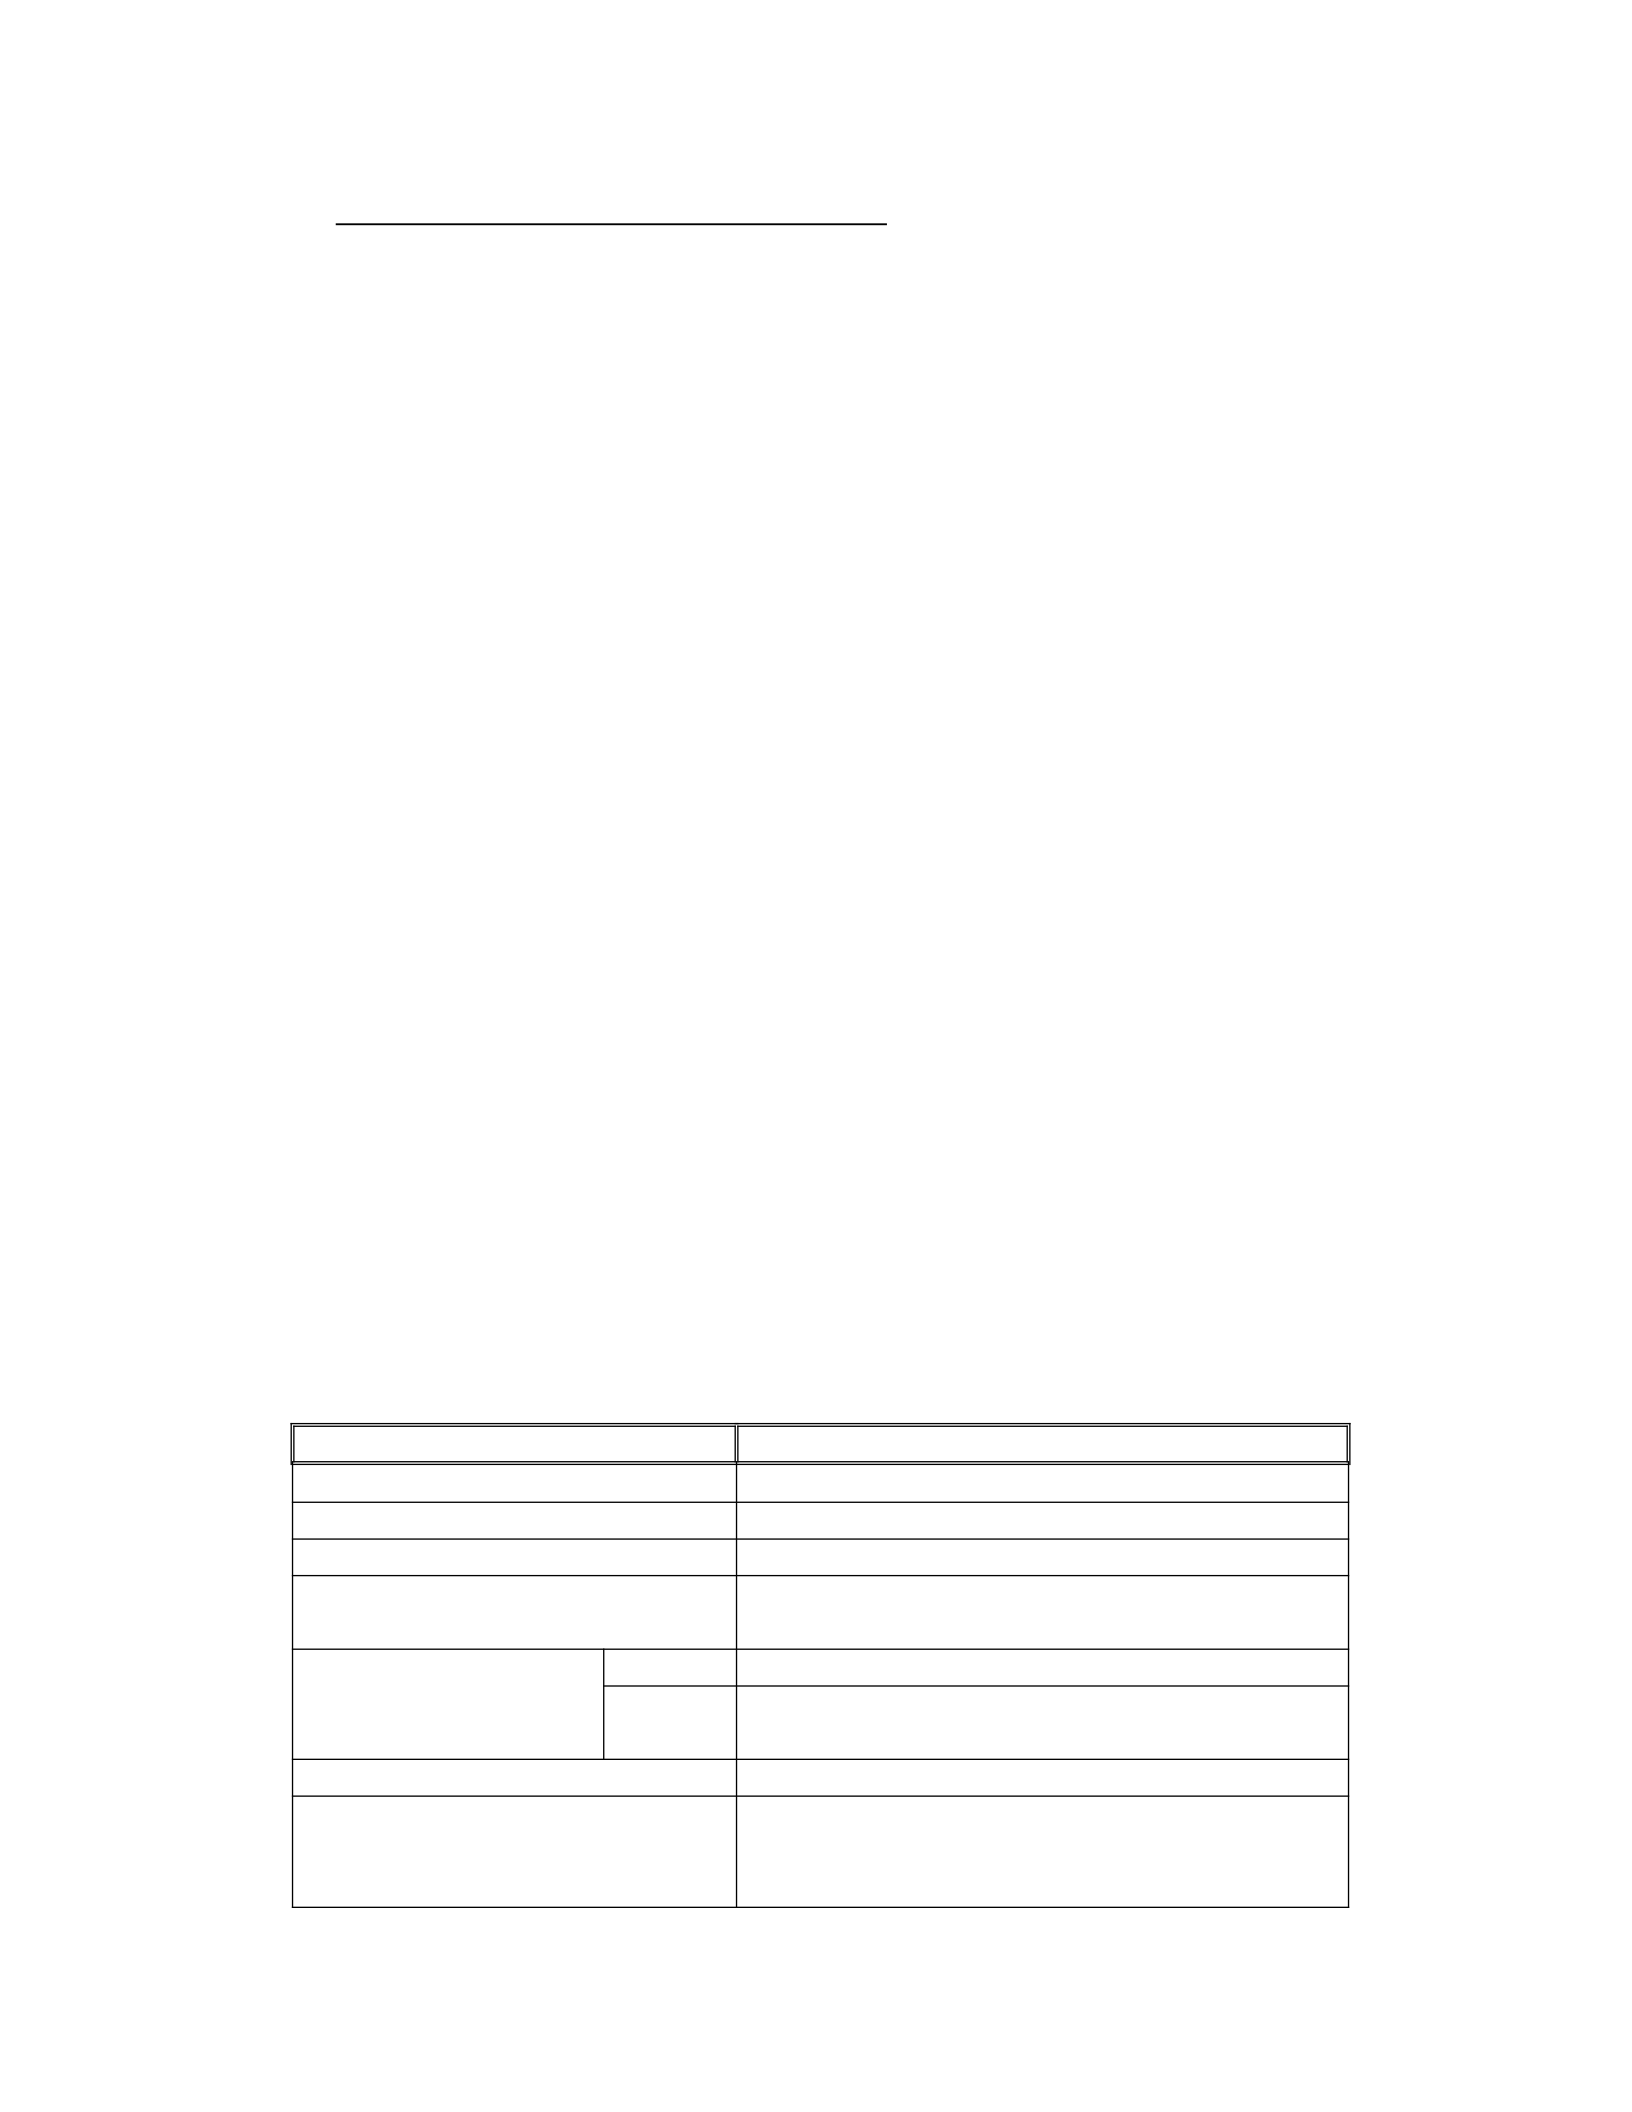
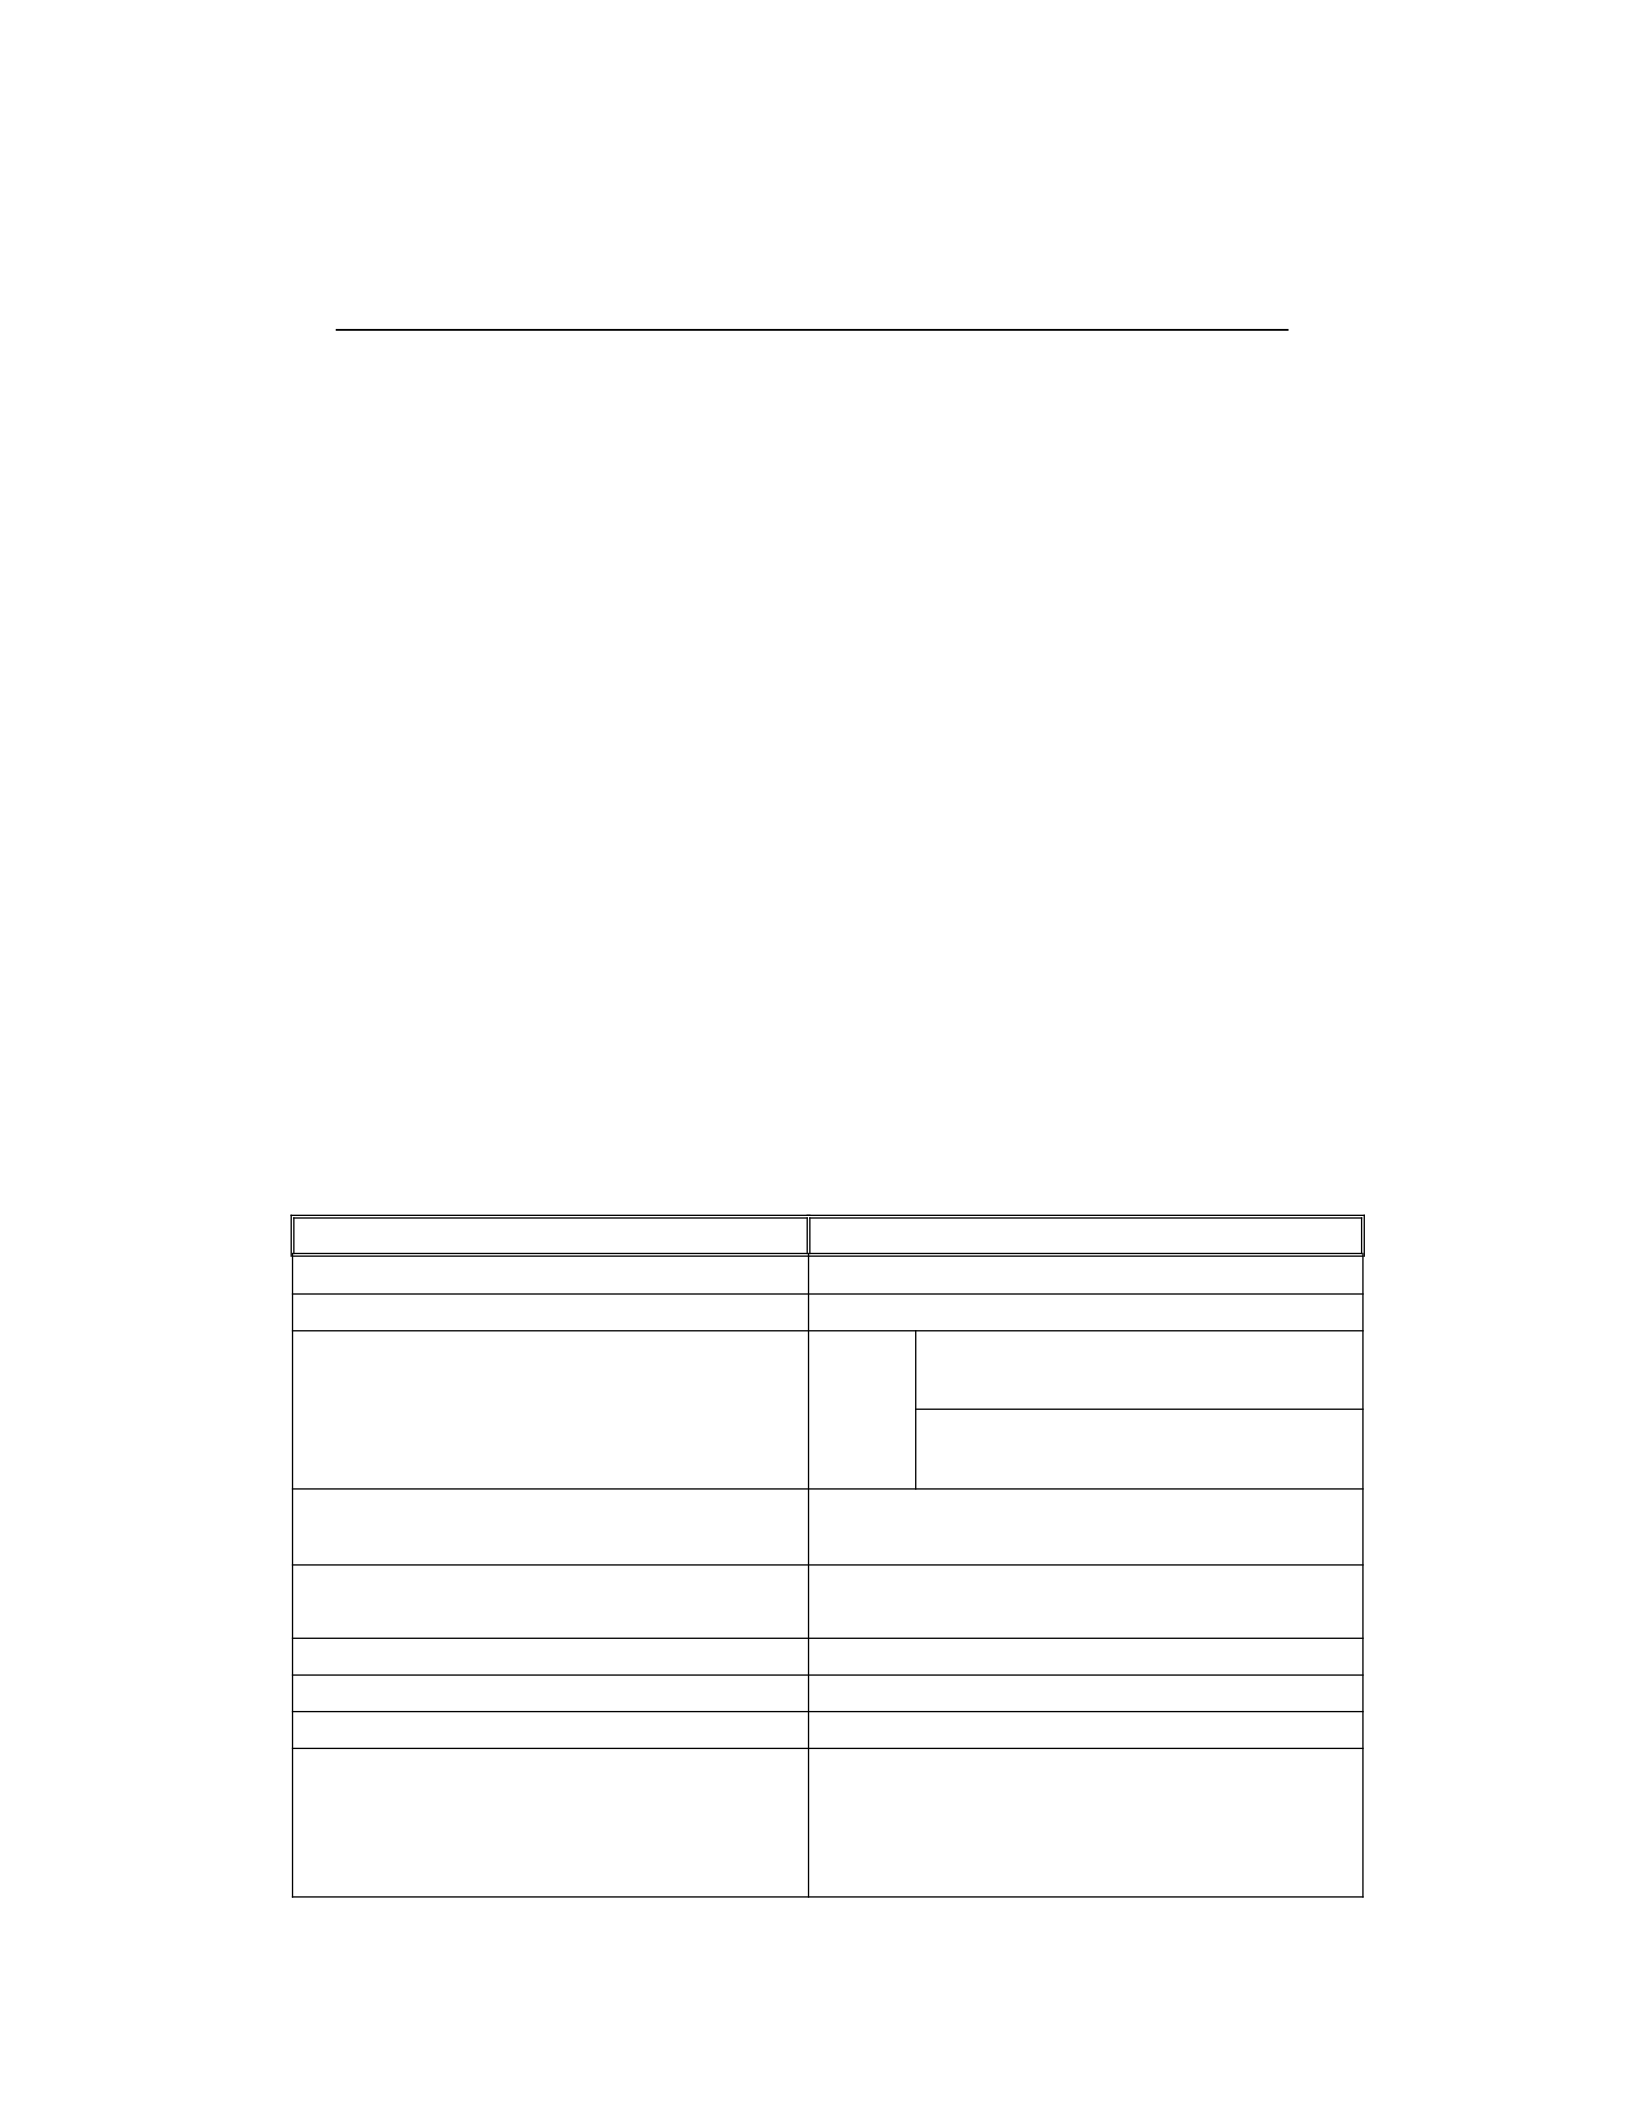
The conditions and configurations of the test days are presented below in Table 1.
The test was conducted on two mission representative aircraft gross weights: a
relatively low gross weight of 16500 lbs., and a relatively high gross weight of
21000 lbs. The test results are presented in Figures A-12 to A-15.
Images of the A-12 and A-13 graphically illustrate the flight control position
of the trim (cycle, pedals, tail rotor impression pitch) and the attitude and power
required of the aircraft (pitch, roll, collective position, engine torque),
respectively, during a 45 ktas test at 21000 lbs. (the least benign beach-based
configuration tested). In general,
Table 1: Conditions and Configuration of Beach-Based Test Days
Parameter Condition/Configuration
Outdoor Air Temperature Range 15 to 19 Celsius
Pressure Height Range –320 to 100 feet
Gross Weight Range of Aircraft 21539 to 16004 lbs.
Aircraft Center of Gravity
Range 365.5 to 353.3 inches
Target Gross Weight
Low 16500 lbs. (no internal weights used)
Tall 21000 Lbs. (4500 Lbs. Internal Ballast
hired)
Rotor Speed 100%
Automatic Flight Control
System Configuration
Stabilizer at automatic mood; Stability
The augmentation, trim, autopilot, and
hydraulic pilot assist functions are activated.
41
no unsatisfactory results were documented. In all cases, the minimum flight
control margin is satisfactory and no critical flight control positions are recorded
(i.e. at all times, at least 10% of the control positions remain). In addition, the
attitude of the aircraft is considered satisfactory, such as the collective position
and the required strength (nothing is considered excessive). Specific results are
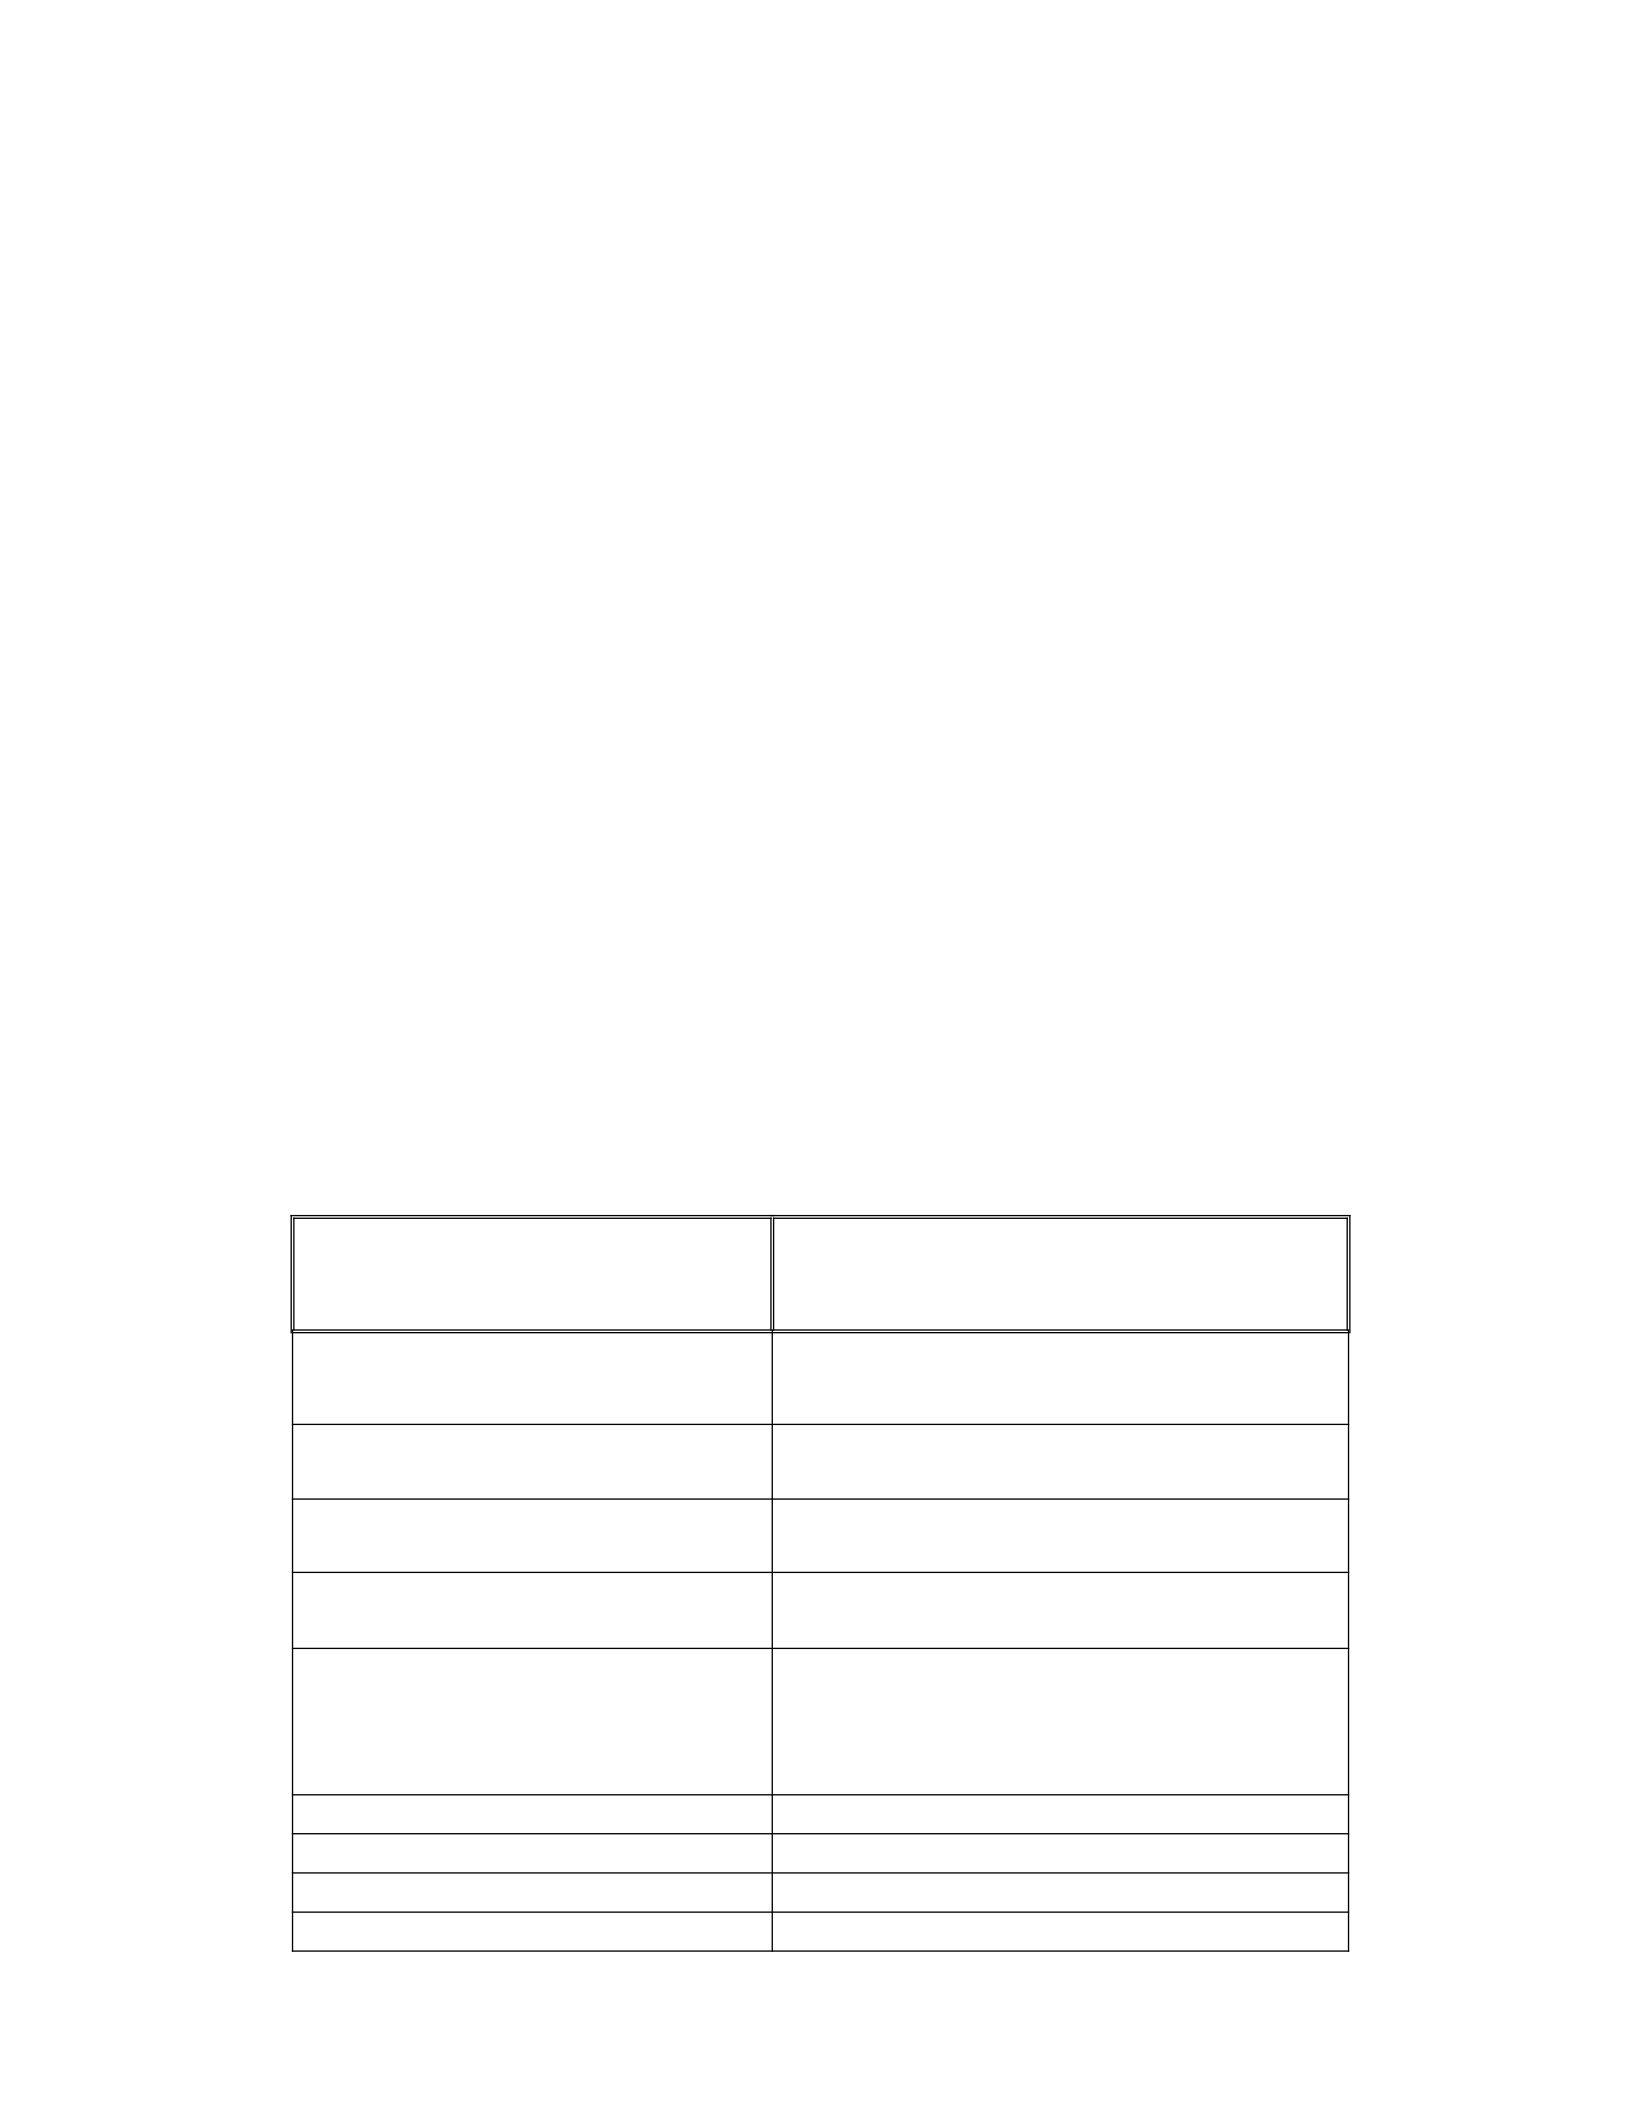
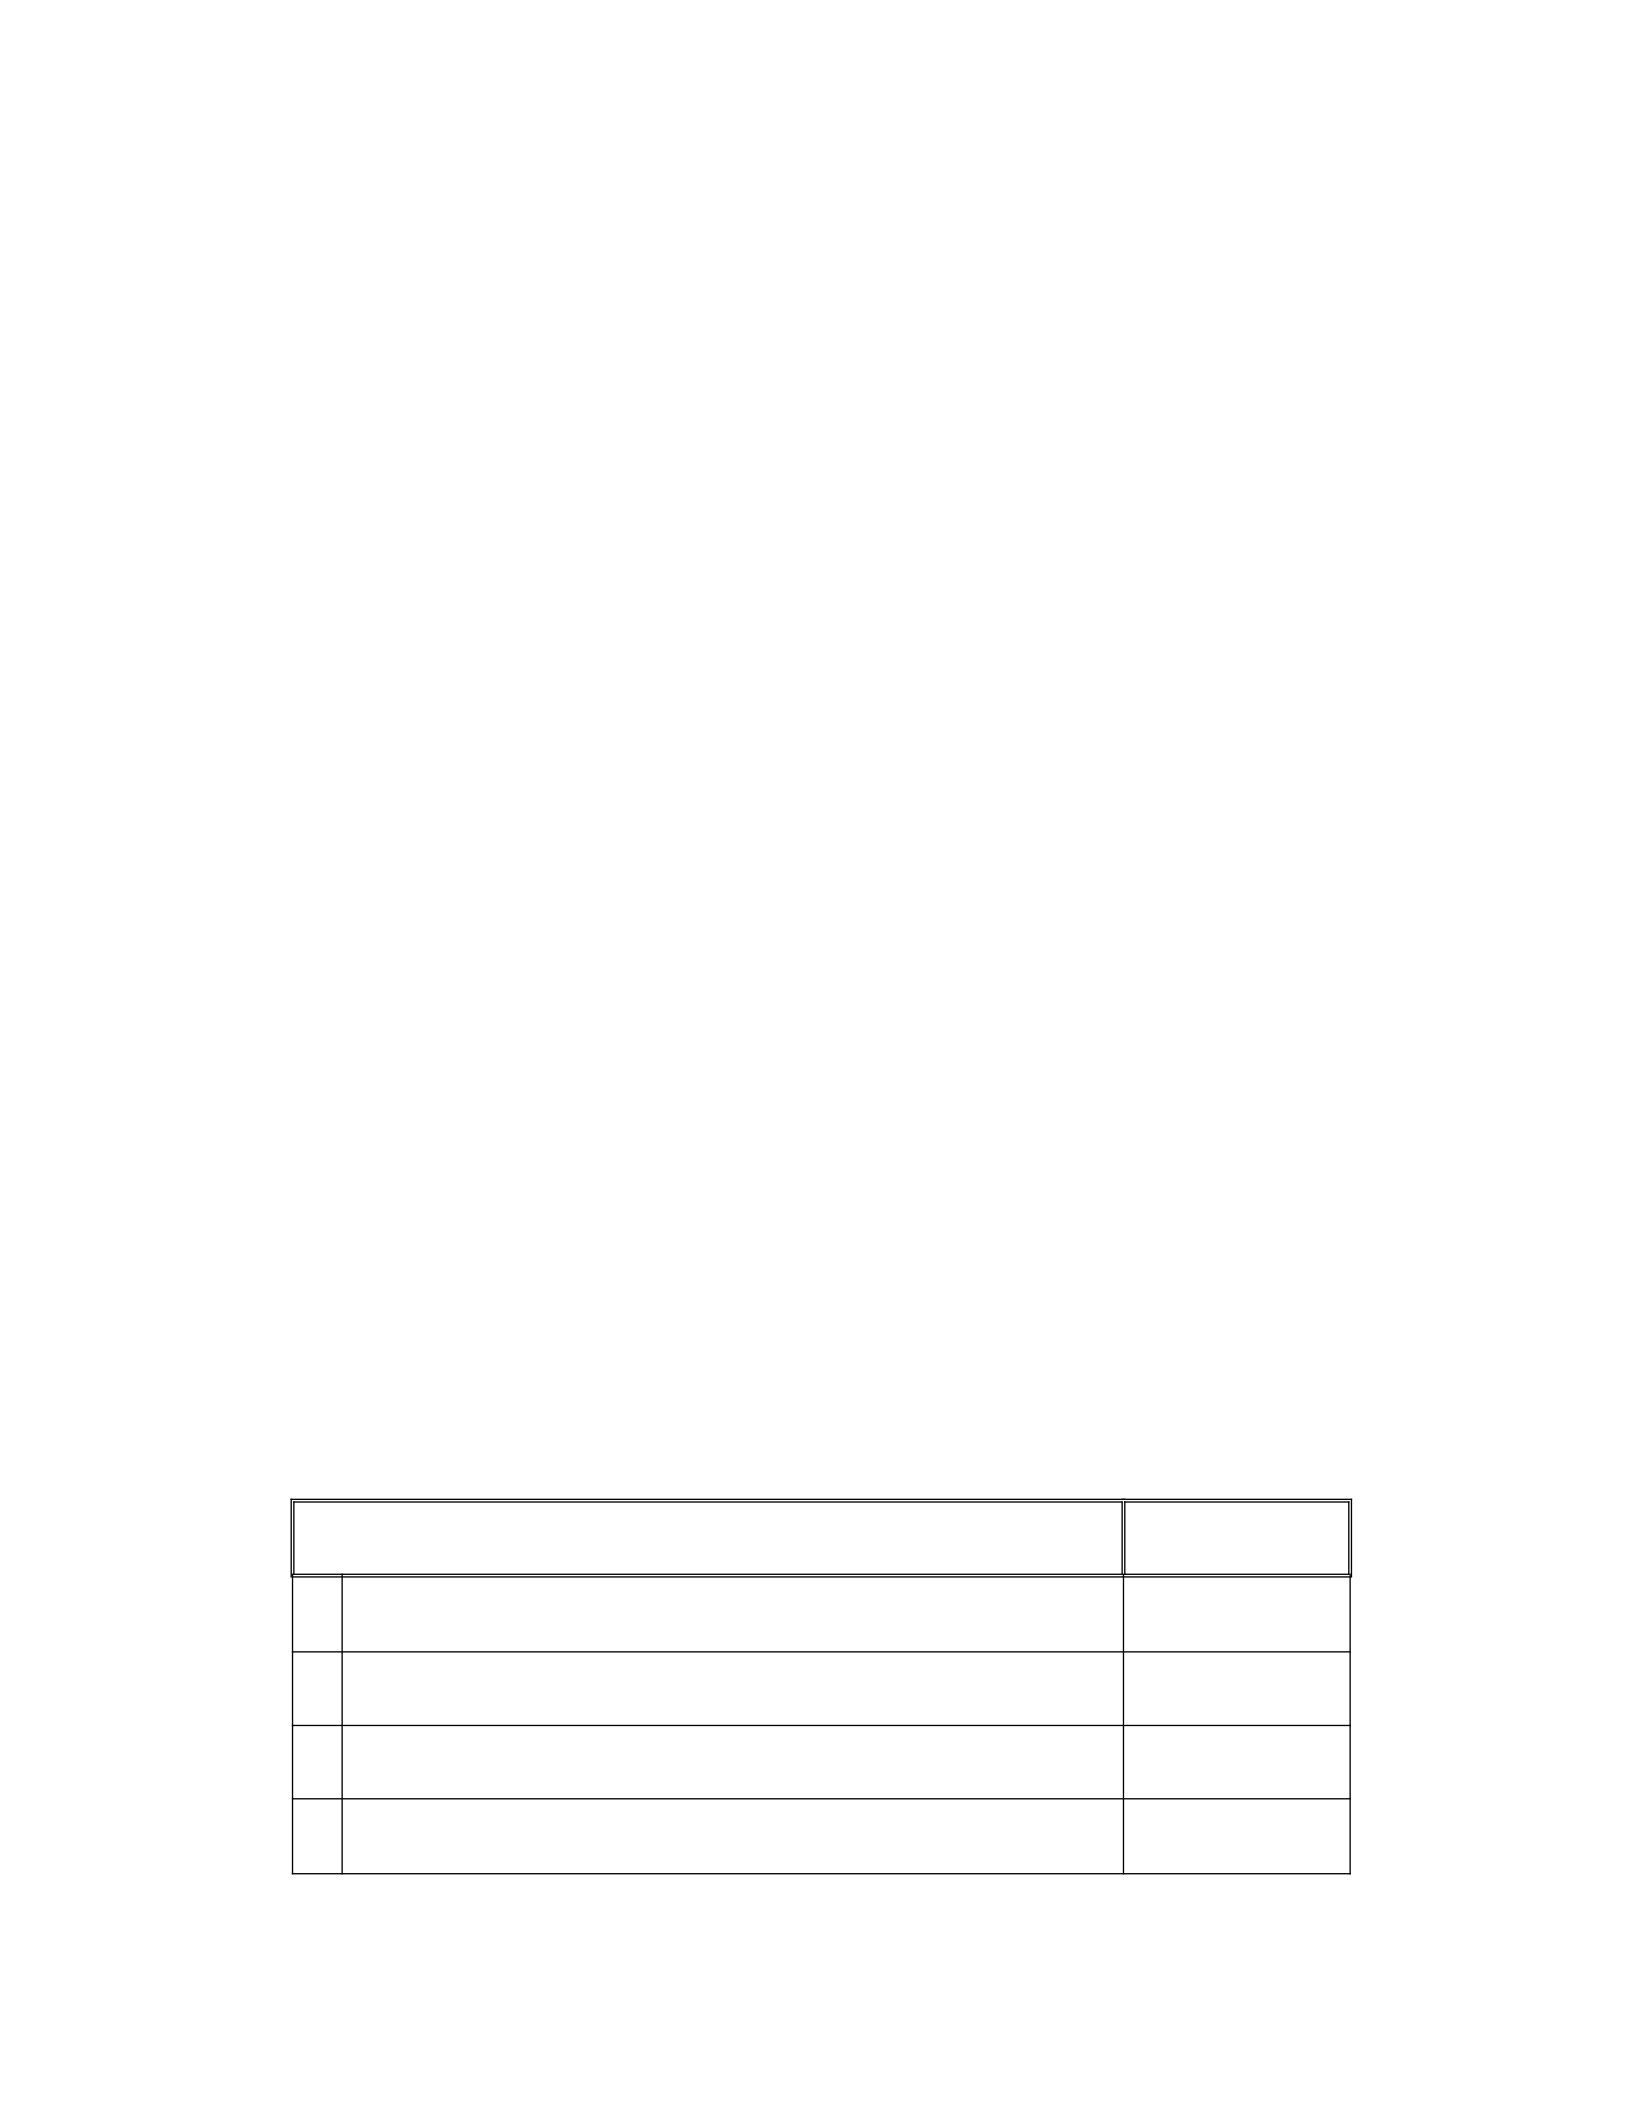
detailed below in Table 2.
The A-14 and A-15 images graphically illustrate the low airspeed handling
quality of the aircraft by presenting the pilot ratings assigned to each wind
condition (azimuth and airspeed) tested. Neither the turbulence nor the pilot-
induced oscillation was observed during the test. Thus, only the quality of
handling and vibration rating are given.
Graphic depictions like this are designed to facilitate the identification of
unsatisfactory wind conditions (azimuth and air velocity), and
Table 2: Aircraft Parameters During Beach-Based Testing
Parameters
(control margin or aircraft
attitude)
Border
(% remaining or documented attitudes,
and azimuth where it occurs)
Minimum longitudinal control
Margin Remaining 26% (from full back) @
300R
Margin kontrol lateral minimum Remaining 14% (from full right) @
120R
Minimum directional control
Margin Remaining 26% (from full left) @ 120R
Impressive margin pitch of the
minimum tail rotor
27% remaining (maximum 100%
available for anti-torque) @ 120R
Margin control collective
Consistently very large on all wind
azimuths tested, with 40 to 47% remaining
altogether
river.
Maximum pitch attitude 6.3 nose up @ 150R
Sikap pitch minimum 0 @ 030R and 330R
Maximum right roll attitude 1 @ 90R
Maximum left roll attitude 6.2 @ 270R
42
potentially dangerous, in relation to the pilot's workload and the quality of the
aircraft handling. They allow the discovery of "critical" wind conditions that can
be emphasized during future tests (e.g. ship launches and development of
recovery wind envelopes).
At 16500 lbs. gross weight (Figure A-14), no critical wind conditions have
been documented. All assigned pilot ratings were HQR-4 or less (mostly HQR-3),
with the exception of four HQR-5 ranks, which were assigned to a wide range of
conditions between 30 and 45 KTAS, with winds from ports/harbors (around 180-
270R). This is most likely due to the tail rotor airflow disruption (and, thus, in
the tail rotor thrust) and the increased pilot workload generated by this
disturbance.
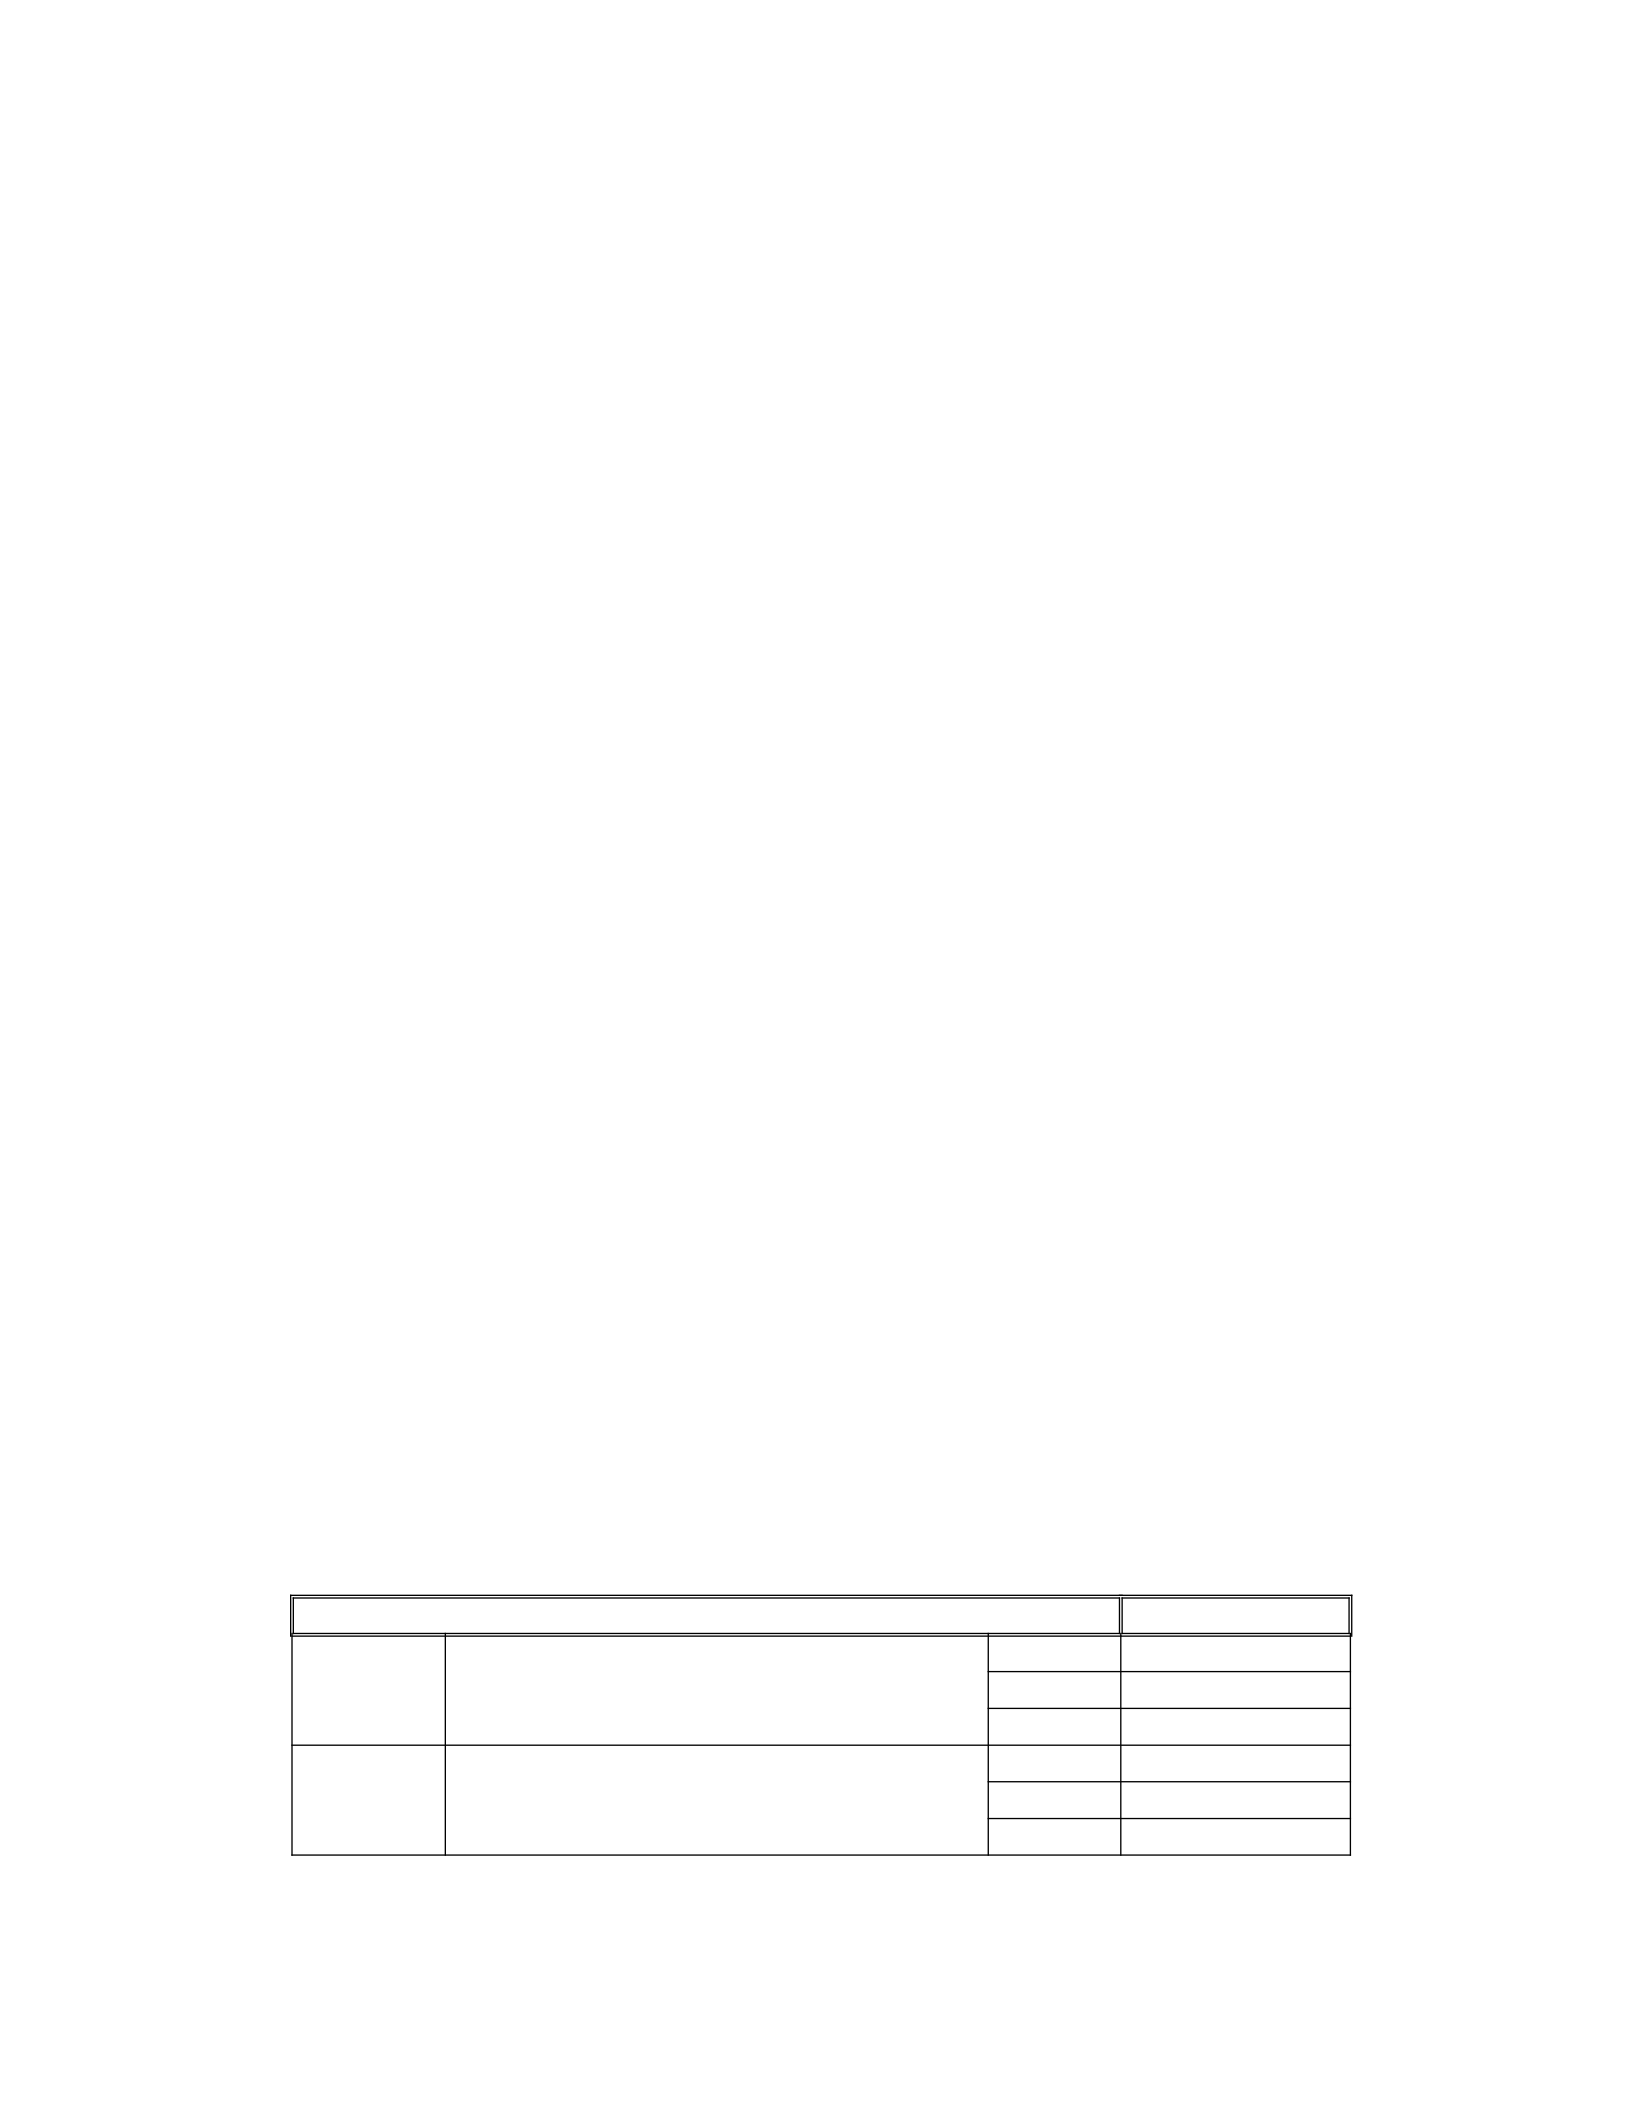
Table 3 below provides specific information about the frequencies used for
each HQR assigned. What is important is that 60% of HQR assignments rate the
pilot's workload at the most minimal, and for satisfactory shortcomings without
improvement.
The vibration rating rating set during the test at 16500 lbs. is more significant.
Although not significant enough to warrant identification
Table 3: HQR Assignment During Shore-Based Testing (16500 lbs.)
HQR Assigned %
Event
2Pilot compensation is not a factor; Lack of negligible
handling quality 15
3Pilot compensation is minimal; Some are a bit unpleasant
Handling quality deficiencies 45
4Moderate pilot compensation; small but annoying
Handling quality deficiencies 30
5Considerable pilot compensation; Lack of quality
handling is quite inappropriate 10
43
For certain critical wind conditions, nearly half (47.5%) of the assignments were
for moderate vibrations that disturbed pilots during one of the most critical flight
phases (i.e. landing). During the landing phase of the flight, after a long and tiring
mission, these vibrations lower the pilot's situational awareness and make
concentration on the demanding landing task on board more difficult. The results
of this vibration level analysis are more significant because the vibration
assessment rating is set in relatively benign conditions, i.e., stable wind conditions
and low gross weight of the aircraft.
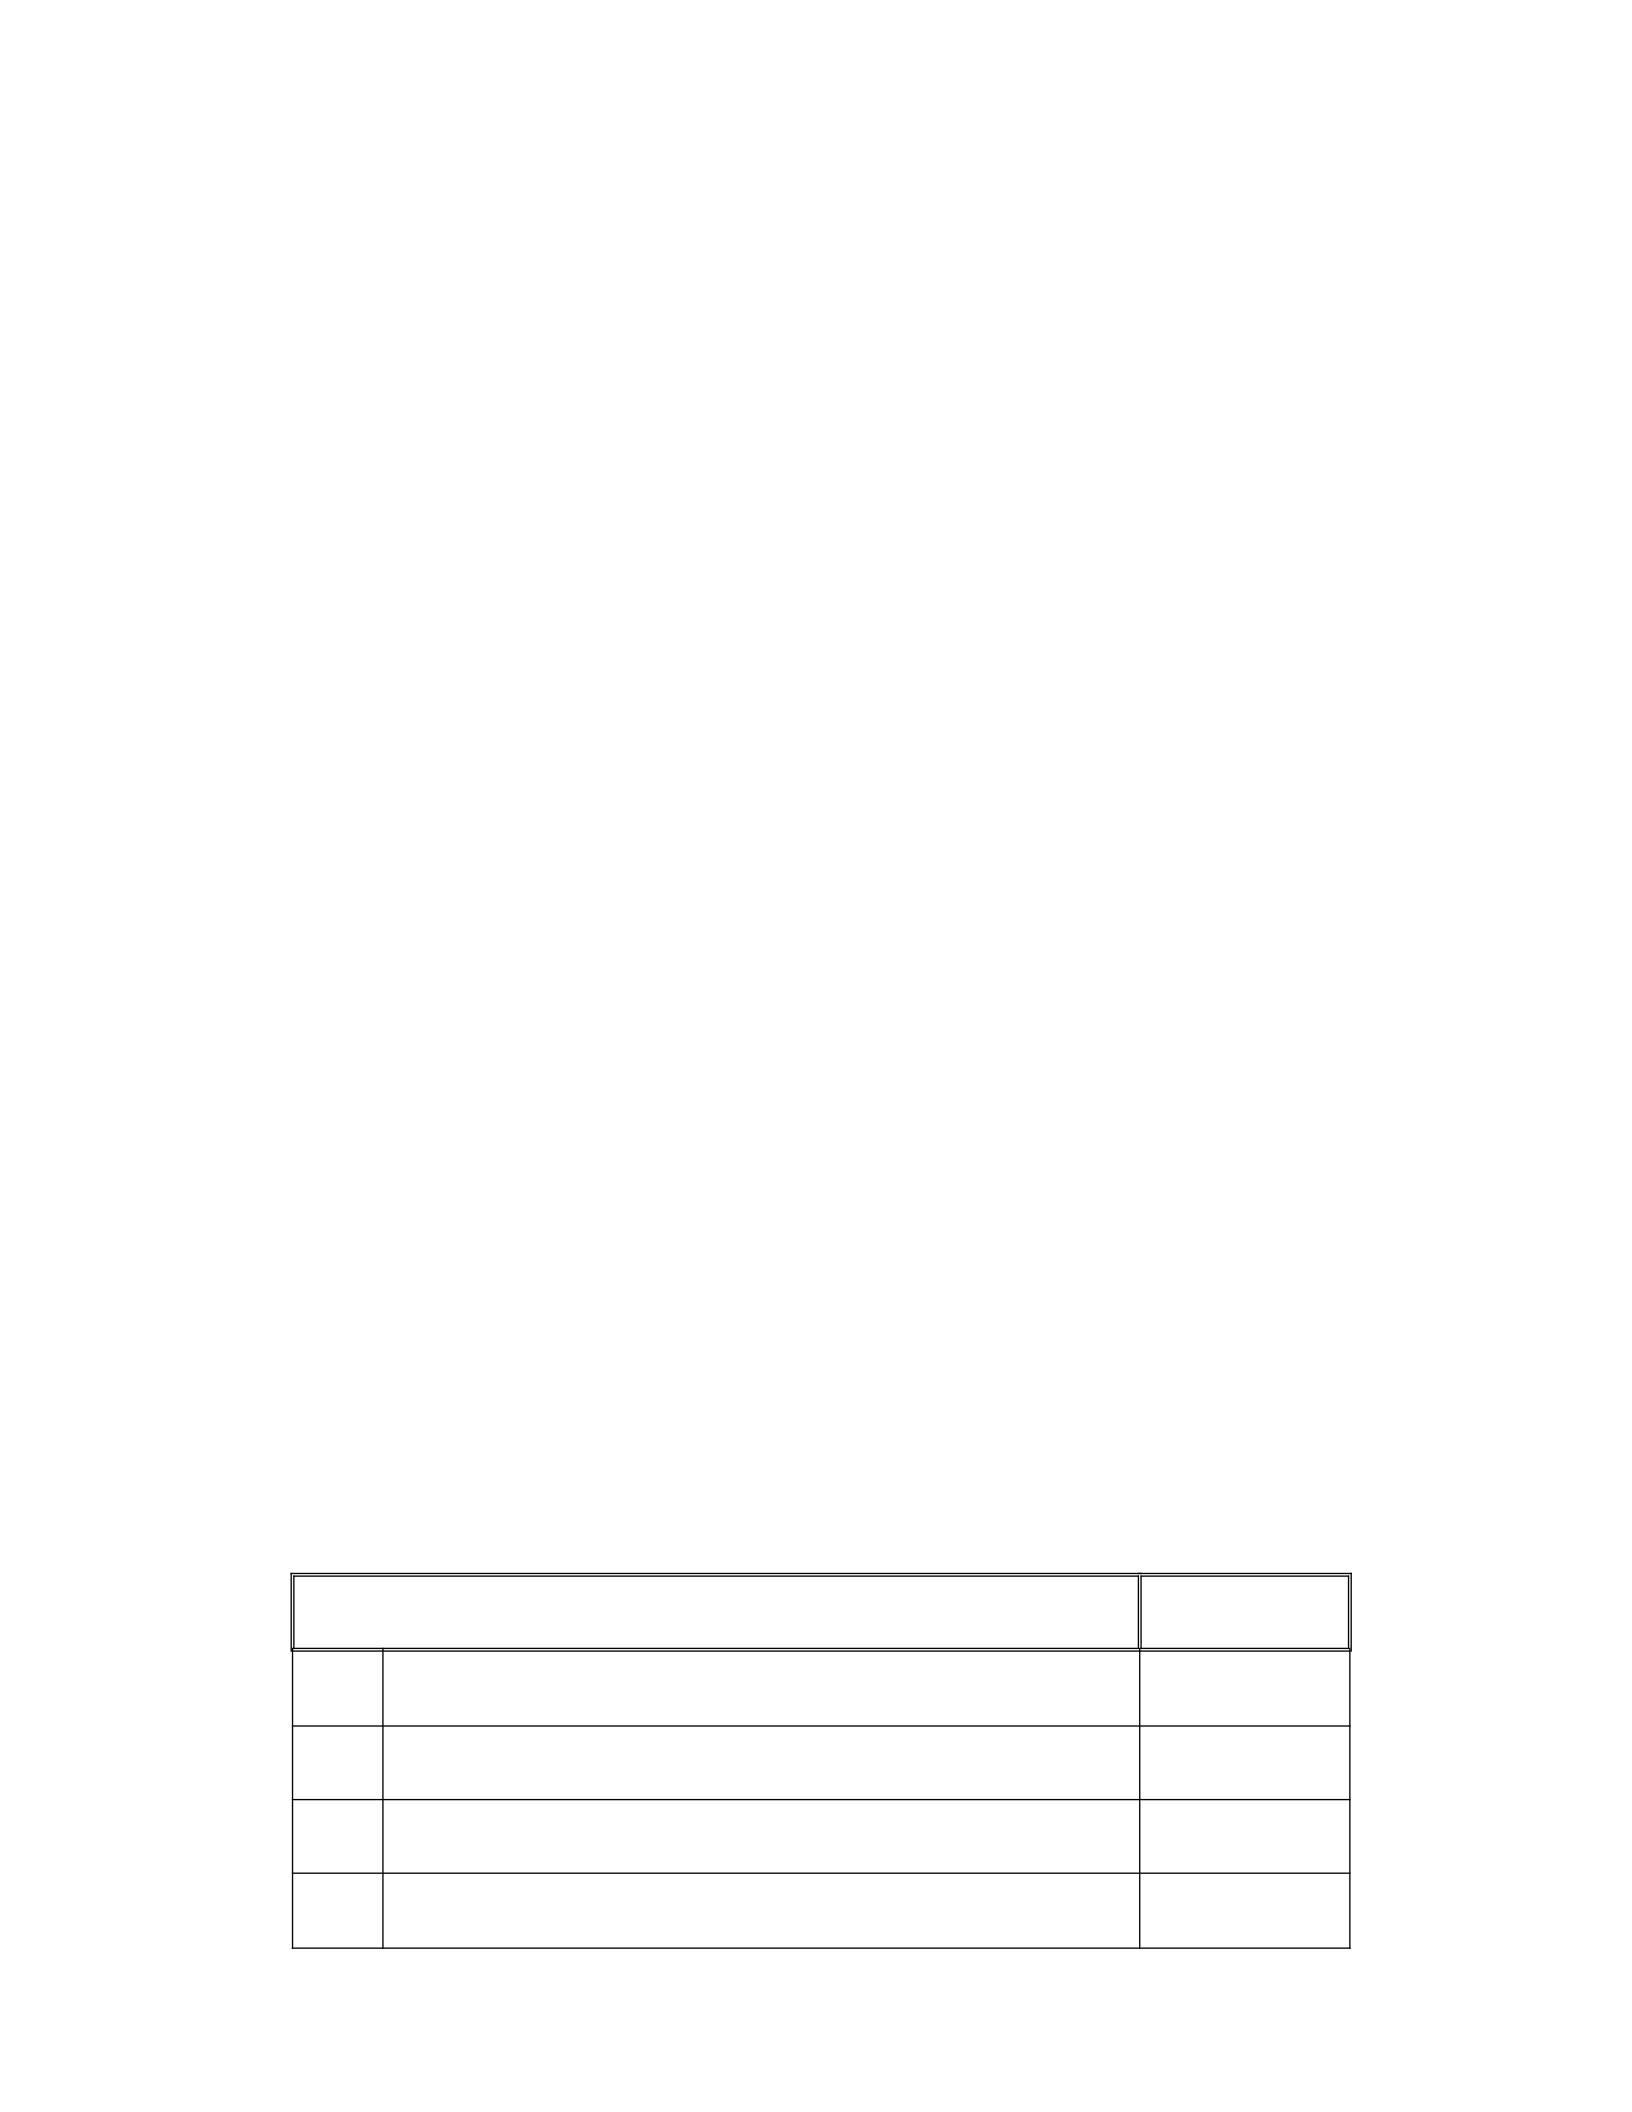
Table 4 below provides specific information on the frequencies used for each
assigned VAR. Similar to HQR assignments, the worst VAR assignments are with
winds from the port quarter (around 200-245R). This is most likely due to the
disturbance of the tail rotor airflow (and, thus, in the thrust of the tail rotor) and
the increased vibration of the fuselage and cockpit generated by this disturbance.
It should also be noted that the worst VAR assignment is not at a maximum wind
speed of 45 KTAS, but at 30 KTAS. This is most likely due to the consumption of
the main rotor vortex, or perhaps the interaction of the main rotor vortex with the
tail rotor or other components of the fuselage. Above and below this airspeed, the
level of cockpit vibration, and the resulting vibration
Table 4: VAR Determination During Shore-Based Testing (16500 lbs.)
VAR Assigned % Incidence
Little It is not visible if it is fully busy;
visible if not occupied
1 7.5
2 10
3 35
Moderate Does not affect the work in a short time 4 30
5 17.5
6 0
44
not so significant.
At 21000 lbs. gross weight (Figure A-15), no critical wind conditions have
been documented. All assigned pilot ratings were HQR-4 or less (most, in fact,
HQR-4), with the exception of four HQR-5 ranks, which were assigned to a wide
range of conditions between 20 and 45 KTAS, with relative winds between 120
and 270.
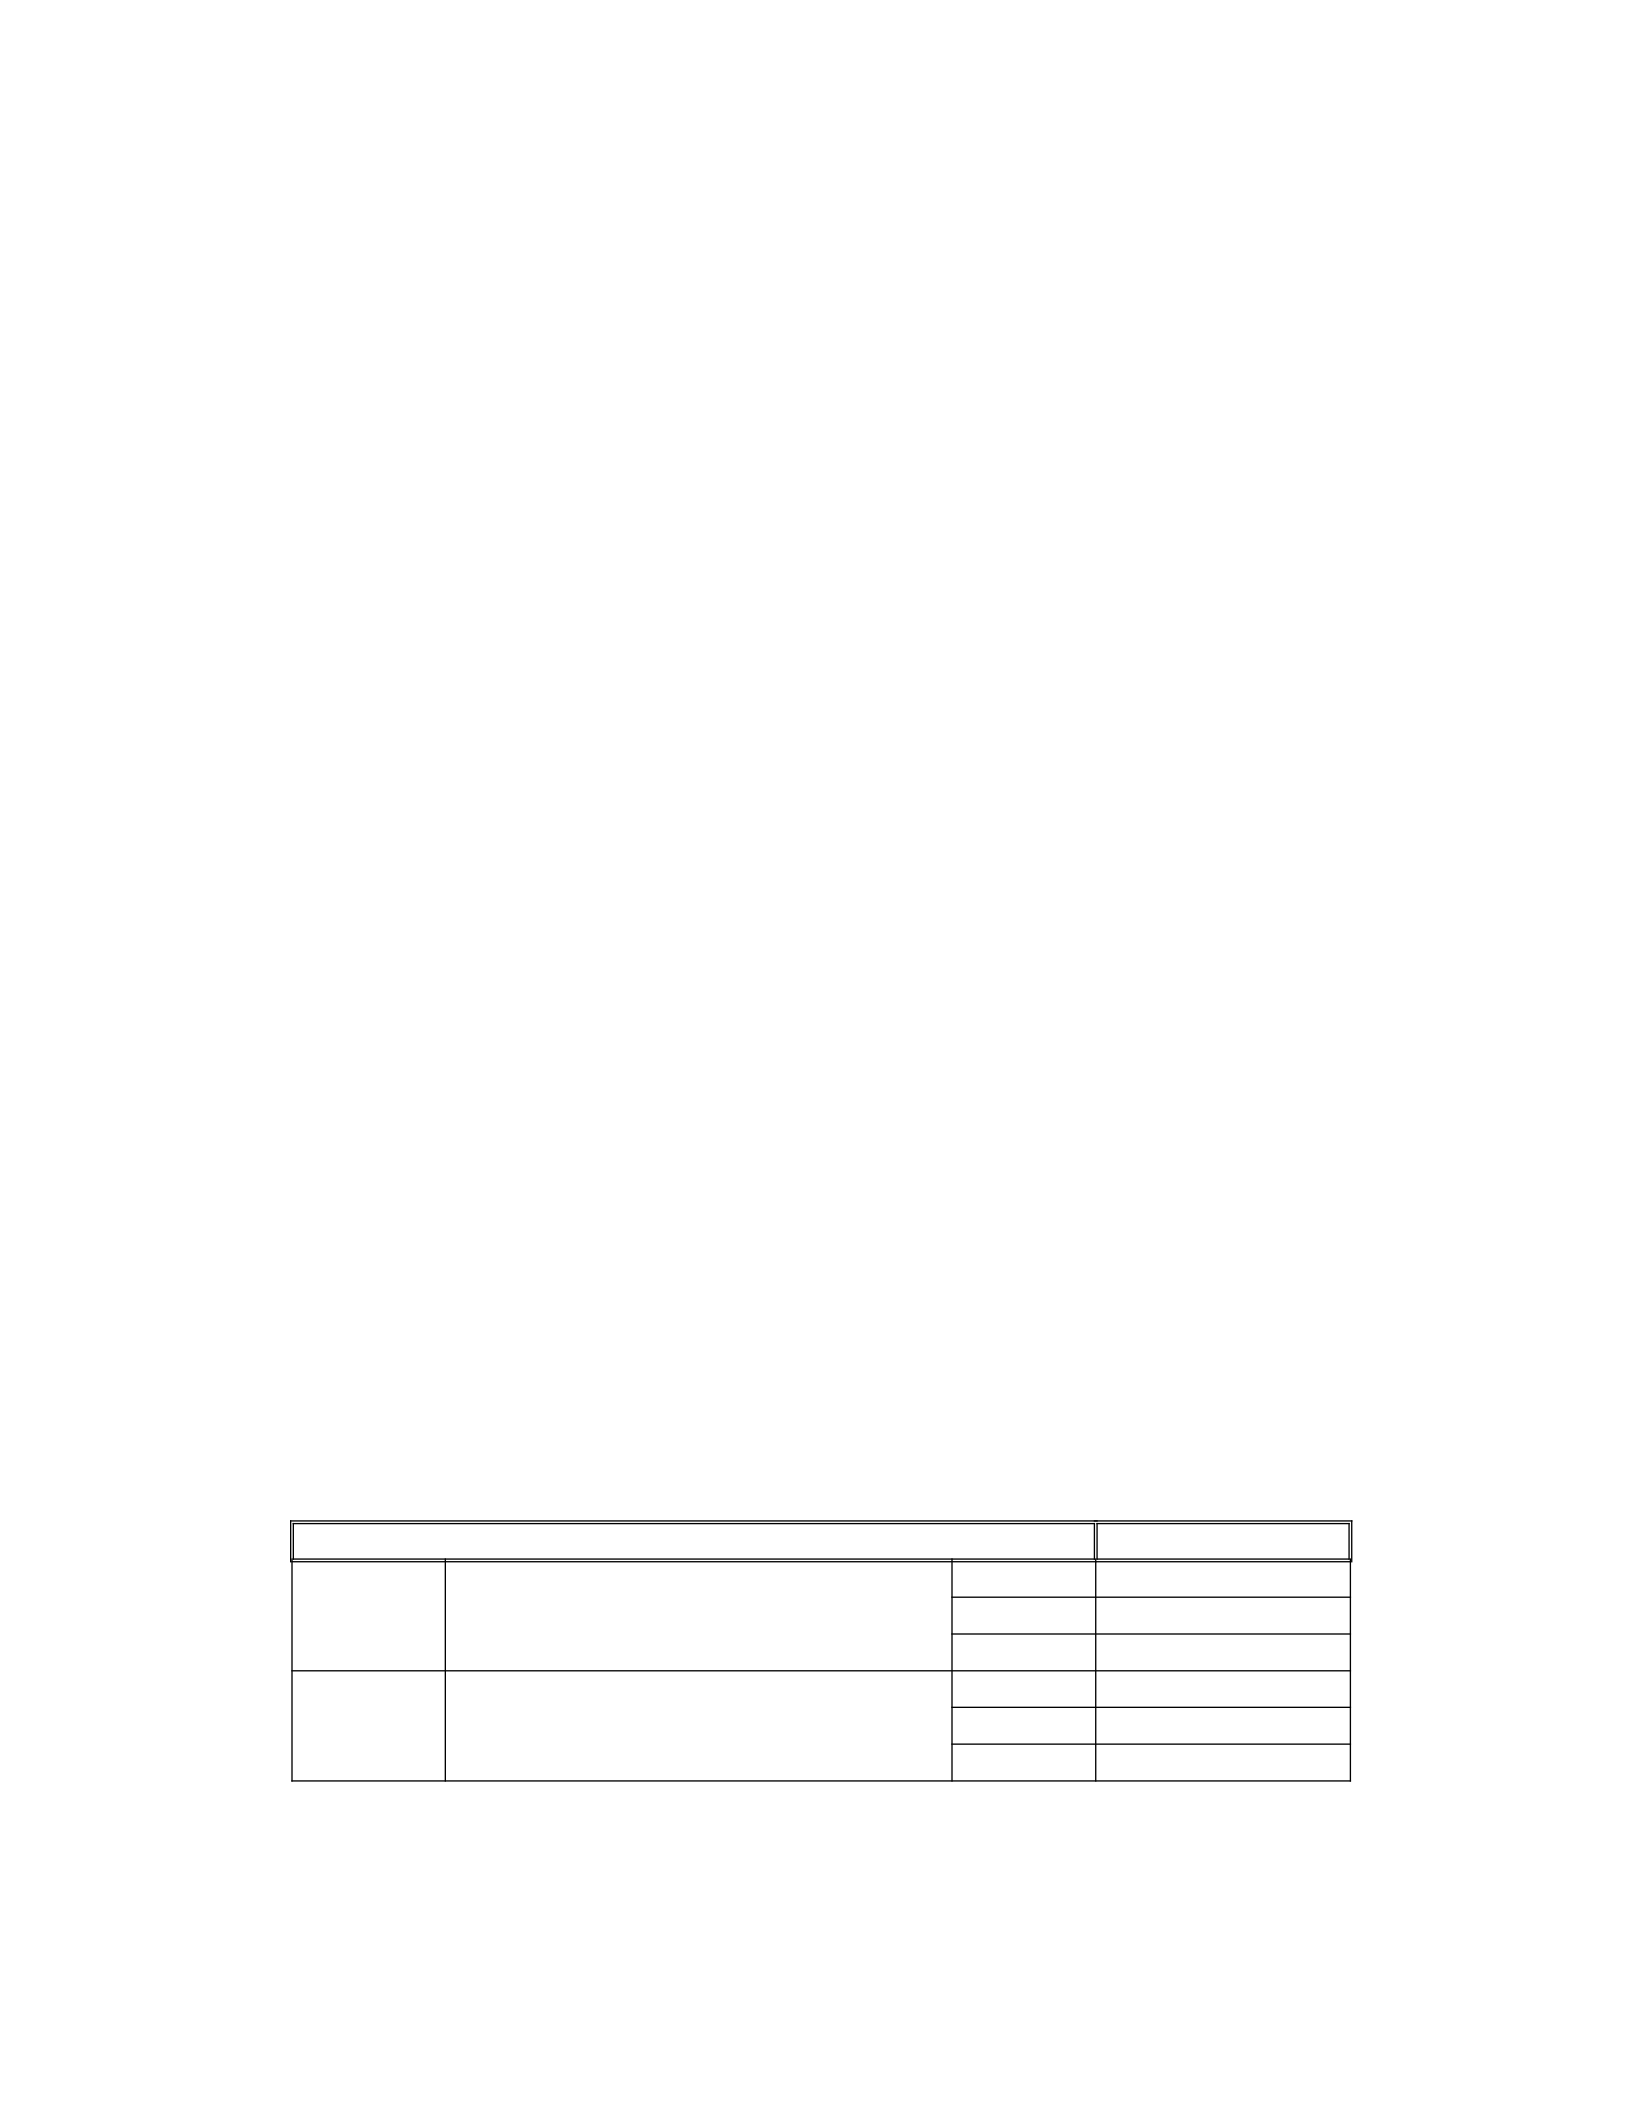
Table 5 below provides specific information about the frequencies used by
each assigned HQR. What is important is that nearly 57% of HQR assignments
rate pilot workload as moderate to moderately large, and for shortcomings that
require improvement. In addition, when compared to the HQR assignment at
16500 lbs. gross weight, which identifies the pilot workload is minimal during
most wind conditions, it is clear that the pilot workload increases with the gross
weight of the aircraft.
The vibration rating rating set during the test at 21000 lbs., again, is more
significant. While not significant enough to warrant the identification of specific
critical wind conditions, the vast majority (more than 73%) of the assignment was
for moderate vibrations which, again, disturbed tired pilots during the critical
landing phase of the flight. Furthermore, when
Table 5: HQR Assignment During Beach-Based Testing (21000 lbs.)
HQR Assigned %
Event
2Pilot compensation is not a factor; Lack of negligible
handling quality 6.67
3Pilot compensation is minimal; Some are a bit unpleasant
Handling quality deficiencies 36.67
4Moderate pilot compensation; small but annoying
Handling quality deficiencies 50
5Considerable pilot compensation; Lack of quality
handling is quite inappropriate 6.67
45
compared to the VAR assignment at 16500 lbs. gross weight, which identifies
moderate vibration during less than half of wind conditions, it is clear that the
cockpit vibration level increases with the gross weight of the aircraft.
Table 6 below provides specific information on the frequencies used for each
assigned VAR. Most of the worst VAR assignments (i.e. VAR-6 assignments) are
observed with winds from a quarter of ports/harbors (about 200-270R). This,
again, is most likely due to the tail rotor airflow disturbances (and, thus, in the tail
rotor thrust) and the increased fuselage and cockpit vibrations generated by these
disturbances. It is also worth noting that 75% of the 30 KTAS points are rated
HQR-5 or 6, and 75% of the 20 KTAS points are rated HQR-4 or 5. Thus, the
worst vibration level was found with winds of 20 to 30 KTAS, again observed.
And again, this is most likely caused by swallowing the main rotor vortex, or
perhaps the interaction of the main rotor vortex with the tail rotor or other
fuselage components. Above and below these airspeeds, the cockpit vibration
level, and the resulting vibration rating rating are not so significant. These wind
speeds (20 to 30 KTAS), where the worst levels of cockpit vibration are observed,
are very significant because such wind speeds are typical of them
Table 6: VAR Determination During Beach-Based Testing (21000 lbs.)
VAR Assigned % Incidence
Little It is not visible if it is fully busy;
visible if not occupied
1 0
2 6.67
3 20
Moderate Does not affect the work in a short
time
4 43.33
5 23.33
6 6.67
46
found on deck during most of the ship's helicopter operations.
3. LAUNCH AND RECOVERY OF WIND ENVELOPE DEVELOPMENT
i. USS BATAAN (LHD 5)
The launch of the day and the development of the recovery wind cover were
carried out aboard the USS Bataan (LHD 5) to points 4, 5, 6 and 7. The conditions
and configurations of the test days are presented below in Table 7.
The test was carried out on a relatively high gross weight of the aircraft which
was 21000 lbs. To achieve this mission a representative of the gross weight of the
aircraft, simulating a full complement of passengers or a large load of internal
cargo, 4500 lbs. of internal weights are used.
The results are presented graphically on Figures A-16 through A-19, and each
depicts the wind conditions above the tested deck (wind speed and azimuth), and
Table 7: Conditions and Configuration of Test Days of USS BATAAN (LHD 5)
Parameter Condition/Configuration
Outdoor Air Temperature Range 15 to 26 Celsius
Pressure Height Range –145 to -132 feet
Sea Country Calm
Ship pitch: 0 to 1
(average 0)
Boat roll: 0 to 2 (average
1)
Wind-Over-Deck Condition Tested
(relative to the bow of the ship)
210R clockwise approx. 145R, 3 to
45 knots
Gross Weight Range of Aircraft 21582 to 20582 lbs. (4500 lbs. Arabic
internal weights are used)
Aircraft Center of Gravity Range 356.1 to 352.9 inches
Target Gross Weight 21000 lbs.
Rotor Speed 100%
Automatic Flight Control System
Configuration
Stabilizer in automatic mode; The
functions of adding stability, trim,
autopilot and hydraulic pilot assistance
are activated.

47
Generate recommended day and night launch and recovery envelopes, for each of
the sites used (points 4, 5, 6, and 7 respectively). In addition, layered on the plot
are the General Launch and the Day and Night Recovery Envelope for LHD-class
ships. Because night evolution was not carried out outside of the Night General
Launch and Recovery Envelope for the sake of reducing the risks inherent in the
operation of the first night ship of MH-60S (and to develop the proficiency of
early night pilots in helicopters), the Night General Launch and Recovery
Envelope for LHD ships was not extended.
A total of 232 (199 day, 33 night) launch and recovery evolutions were
performed, and almost all were documented as satisfactory and rated PRS-1 or
PRS-2. Only one unsatisfactory WOD condition (PRS-3) was documented during
the entire LHD 5 testing period. All evolutions performed for spot 4 (59 days, 12
nights), spot 5 (51 days, 12 nights), and spot 6 (46 days, 4 nights), were rated PRS
satisfactory (PRS-1 or PRS-2). All the evolutions carried out to find 7 tests (43
days, 5 nights), with two exceptions, were rated PRS satisfactory (PRS-1 or PRS-
2). Typically, the pilot's workload increases as the relative wind azimuth increases
to the right of the ship, mostly due to turbulent airflow up and over the edge of the
starboard deck (points 4 and 5), or above and around the large superstructure on
the starboard side of the ship (points 6 and 7). In general, during approaches to
points 5, 6, and 7, with right-hand winds of more than 25 from the bow, at 20
knots and greater, significant turbulence and cuts are noted, which tend to
increase the pilot's workload during the maintenance of the slope of the final
approach, and

48
on-site position maintenance. Such cuts and turbulence at point 7, led to the only
determination of the PRS-3 rating during the testing of the LHD ship.
Slope maintenance was qualitatively evaluated on the final approach to point
7, with winds relative to the right from 40 at 35 knots (Table B-8, Events 257
and 259). At the short end (within 75 feet of the edge of the harbor deck), the
aircraft experienced a large and sudden loss of altitude (10 to 20 feet in 1/2
second). A direct collective increase of 1 to 2", up to approximately 105% of
torque, followed rapidly by a collective reduction of 1 to 2", is required to
withstand the induced rate of descent and re-establish a safe slope of glide for
landing. Another approach for spot 7 was created, under the same ambient
conditions, to verify unsatisfactory rating assignments, and the same results were
documented. The difficulties associated with the maintenance of the slope, and the
unexpected collective input required to withstand the rate of descent and maintain
the slope of the slide at the short end up to point 7, under these ambient
conditions, are considered unacceptable by fleet pilots under typical operational
conditions. As a result, a PRS-3 rating was given for wind conditions above this
deck during the operation to point 7. Because these data points were successfully
conducted only under controlled test conditions, using proven build-up testing
techniques, these data points were not included in the recommended day launch
and recovery envelope for MH-60S helicopters to see 7, aboard LHD-5 class
ships.
Position maintenance was qualitatively evaluated at points 5, 6, and 7, with
relative winds from 340 to 360, at 35 to 40 knots (Table B-8, Events 37, 45, and
49 to 56). Significant airframe (due to moderate cuts and

49
turbulence) is noted while maintaining the position at all points, and most
significant at point 6. Also noted are the resulting cockpit vibrations which, in
places 5 and 7, are rated VAR 6, and, in place 6, are rated VAR 7. While
maintenance of the position above the venue is possible 2 , feet with
(1/2" 1/2 ),
the turbulence and vibration recorded make this a mentally
and physically exhausting regime that will ultimately result in
impaired ability to make a safe landing if an extended hover
( -2 ). is required PRS is assigned Also noted is a sustained moderate cut
while on deck in place 6. The levels of turbulence and vibration documented in
the cockpit during wind conditions above this deck represent the maximum
allowed for PRS-2 rating determination. Turbulence or higher levels of cockpit
vibration would be considered unsatisfactory, and conditions resulting in these
levels would not be included in the recommended day launches and recovery
shrouds for MH-60S helicopters to points 5, 6, and 7, aboard LHD-5 class ships.
The power requirements, and associated pilot workload during fuselage
torsional limit maintenance, were evaluated during launch from points 4, 5, 6, and
7, with tailwinds of 5 to 10 knots (Table B-8, Event numbers 138 to 146). No
significant quality deficiency (i.e. unsatisfactory pilot rating) was recorded, and
all ratings awarded were PRS-1 or PRS-2. However, it is documented that a 20 to
25% increase in torque in ground effect power (IGE) is required to prevent
settling below the edge of the deck during takeoff, and to achieve a satisfactory
climb after launch (during a 10 to 10
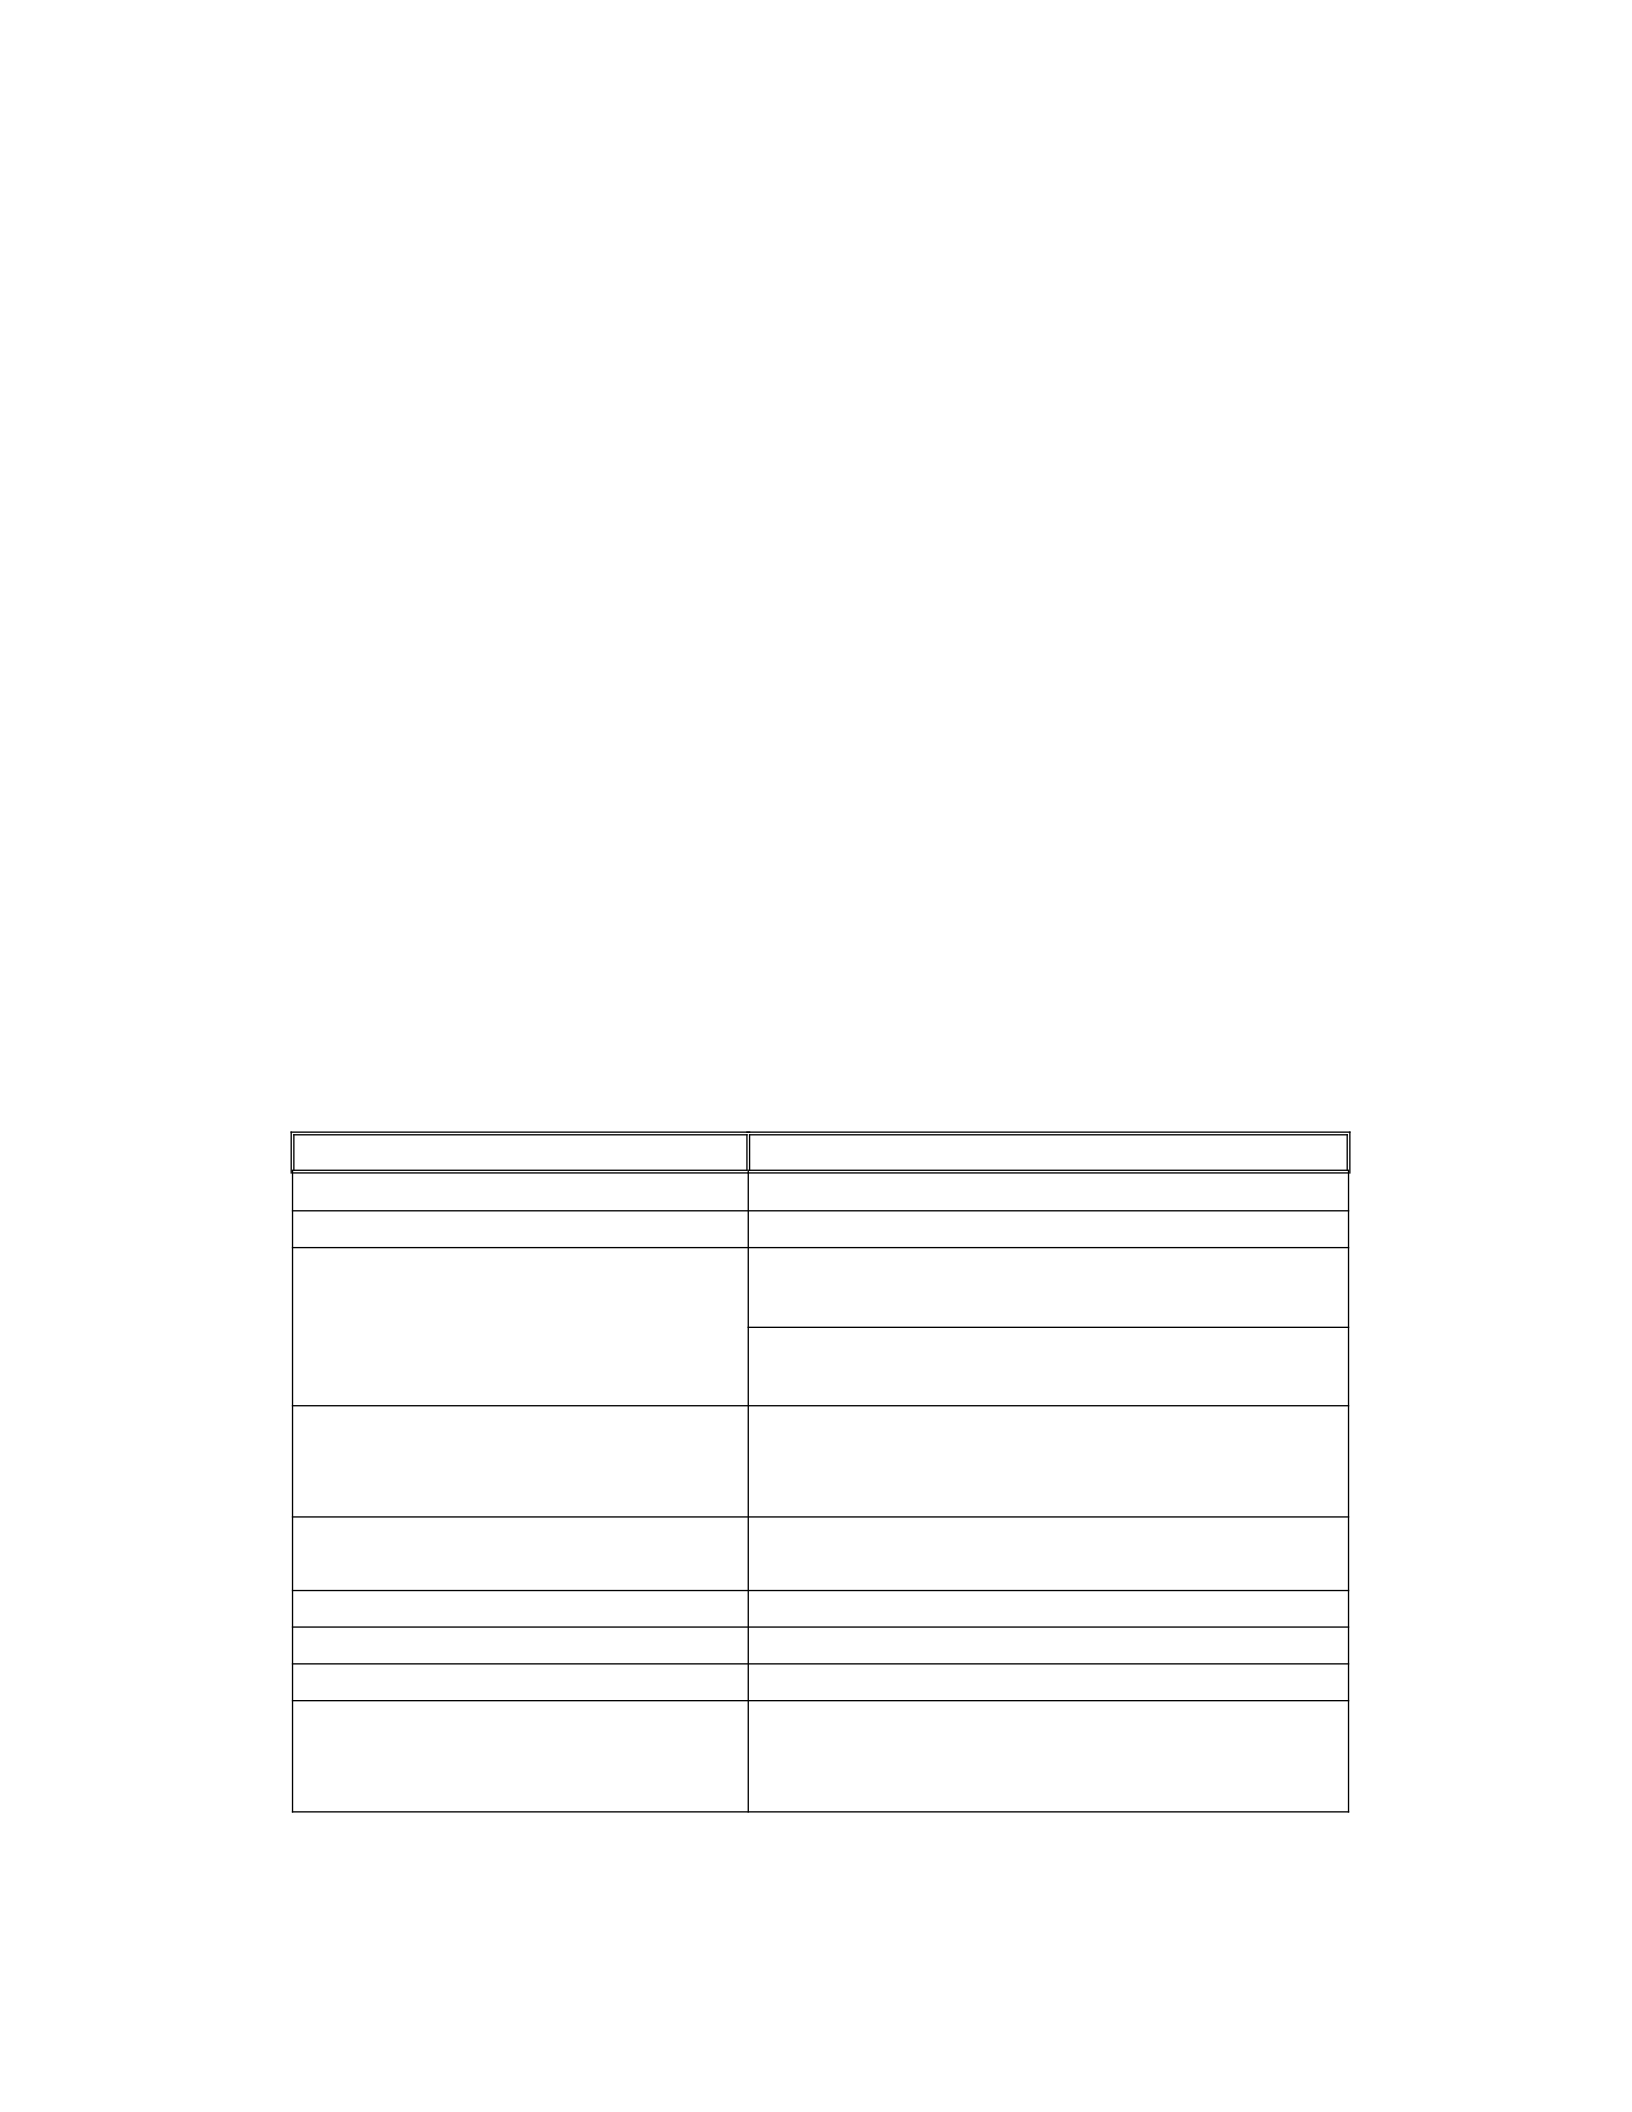
50
An increase in torque required of 15% will be expected). This increase in power
required during tailwind takeoff is most likely due to the delayed onset of
forward-indicated airspeed and the longer-than-usual requirement for hover out of
ground effect (OGE) power.
ii. USNS CONCORD (T-AFS 5)
Day and night launches and the development of the recovery wind cover were
carried out aboard the ship USNS CONCORD (T-AFS 5) during the port and
starboard approach and departure to the ship's deck. The conditions and
configurations of the test days are presented below in Table 8.
The test was carried out on a relatively high gross weight of the aircraft which
was 21000 lbs. To accomplish this mission, representatives of dirty heavy aircraft
Table 8: Conditions and Configuration of USNS CONCORD Test Days (T-
AFS 5)
Parameter Condition/Configuration
Outdoor Air Temperature Range 18 to 30 Celsius
Pressure Height Range –150 to 220 feet
Sea Country
1 to 6 of ship pitch (average
2)
1 to 10 boat rolls (average 3)
Wind-Over-Deck Conditions
Tested (relative to the bow of the
ship)
1 to 38 knots, circling the entire azimuth of
the wind 360
Gross Weight Range of Aircraft 21582 to 20582 lbs. (4500 lbs. internal
ballast used)
Aircraft Center of Gravity Range 356.1 to 352.9 inches
Target Gross Weight 21000 lbs.
Rotor Speed 100%
Automatic Flight Control
System Configuration
Stabilizer in automatic mode; Stability
The augmentation, trim, autopilot, and
hydraulic pilot assist functions are activated.
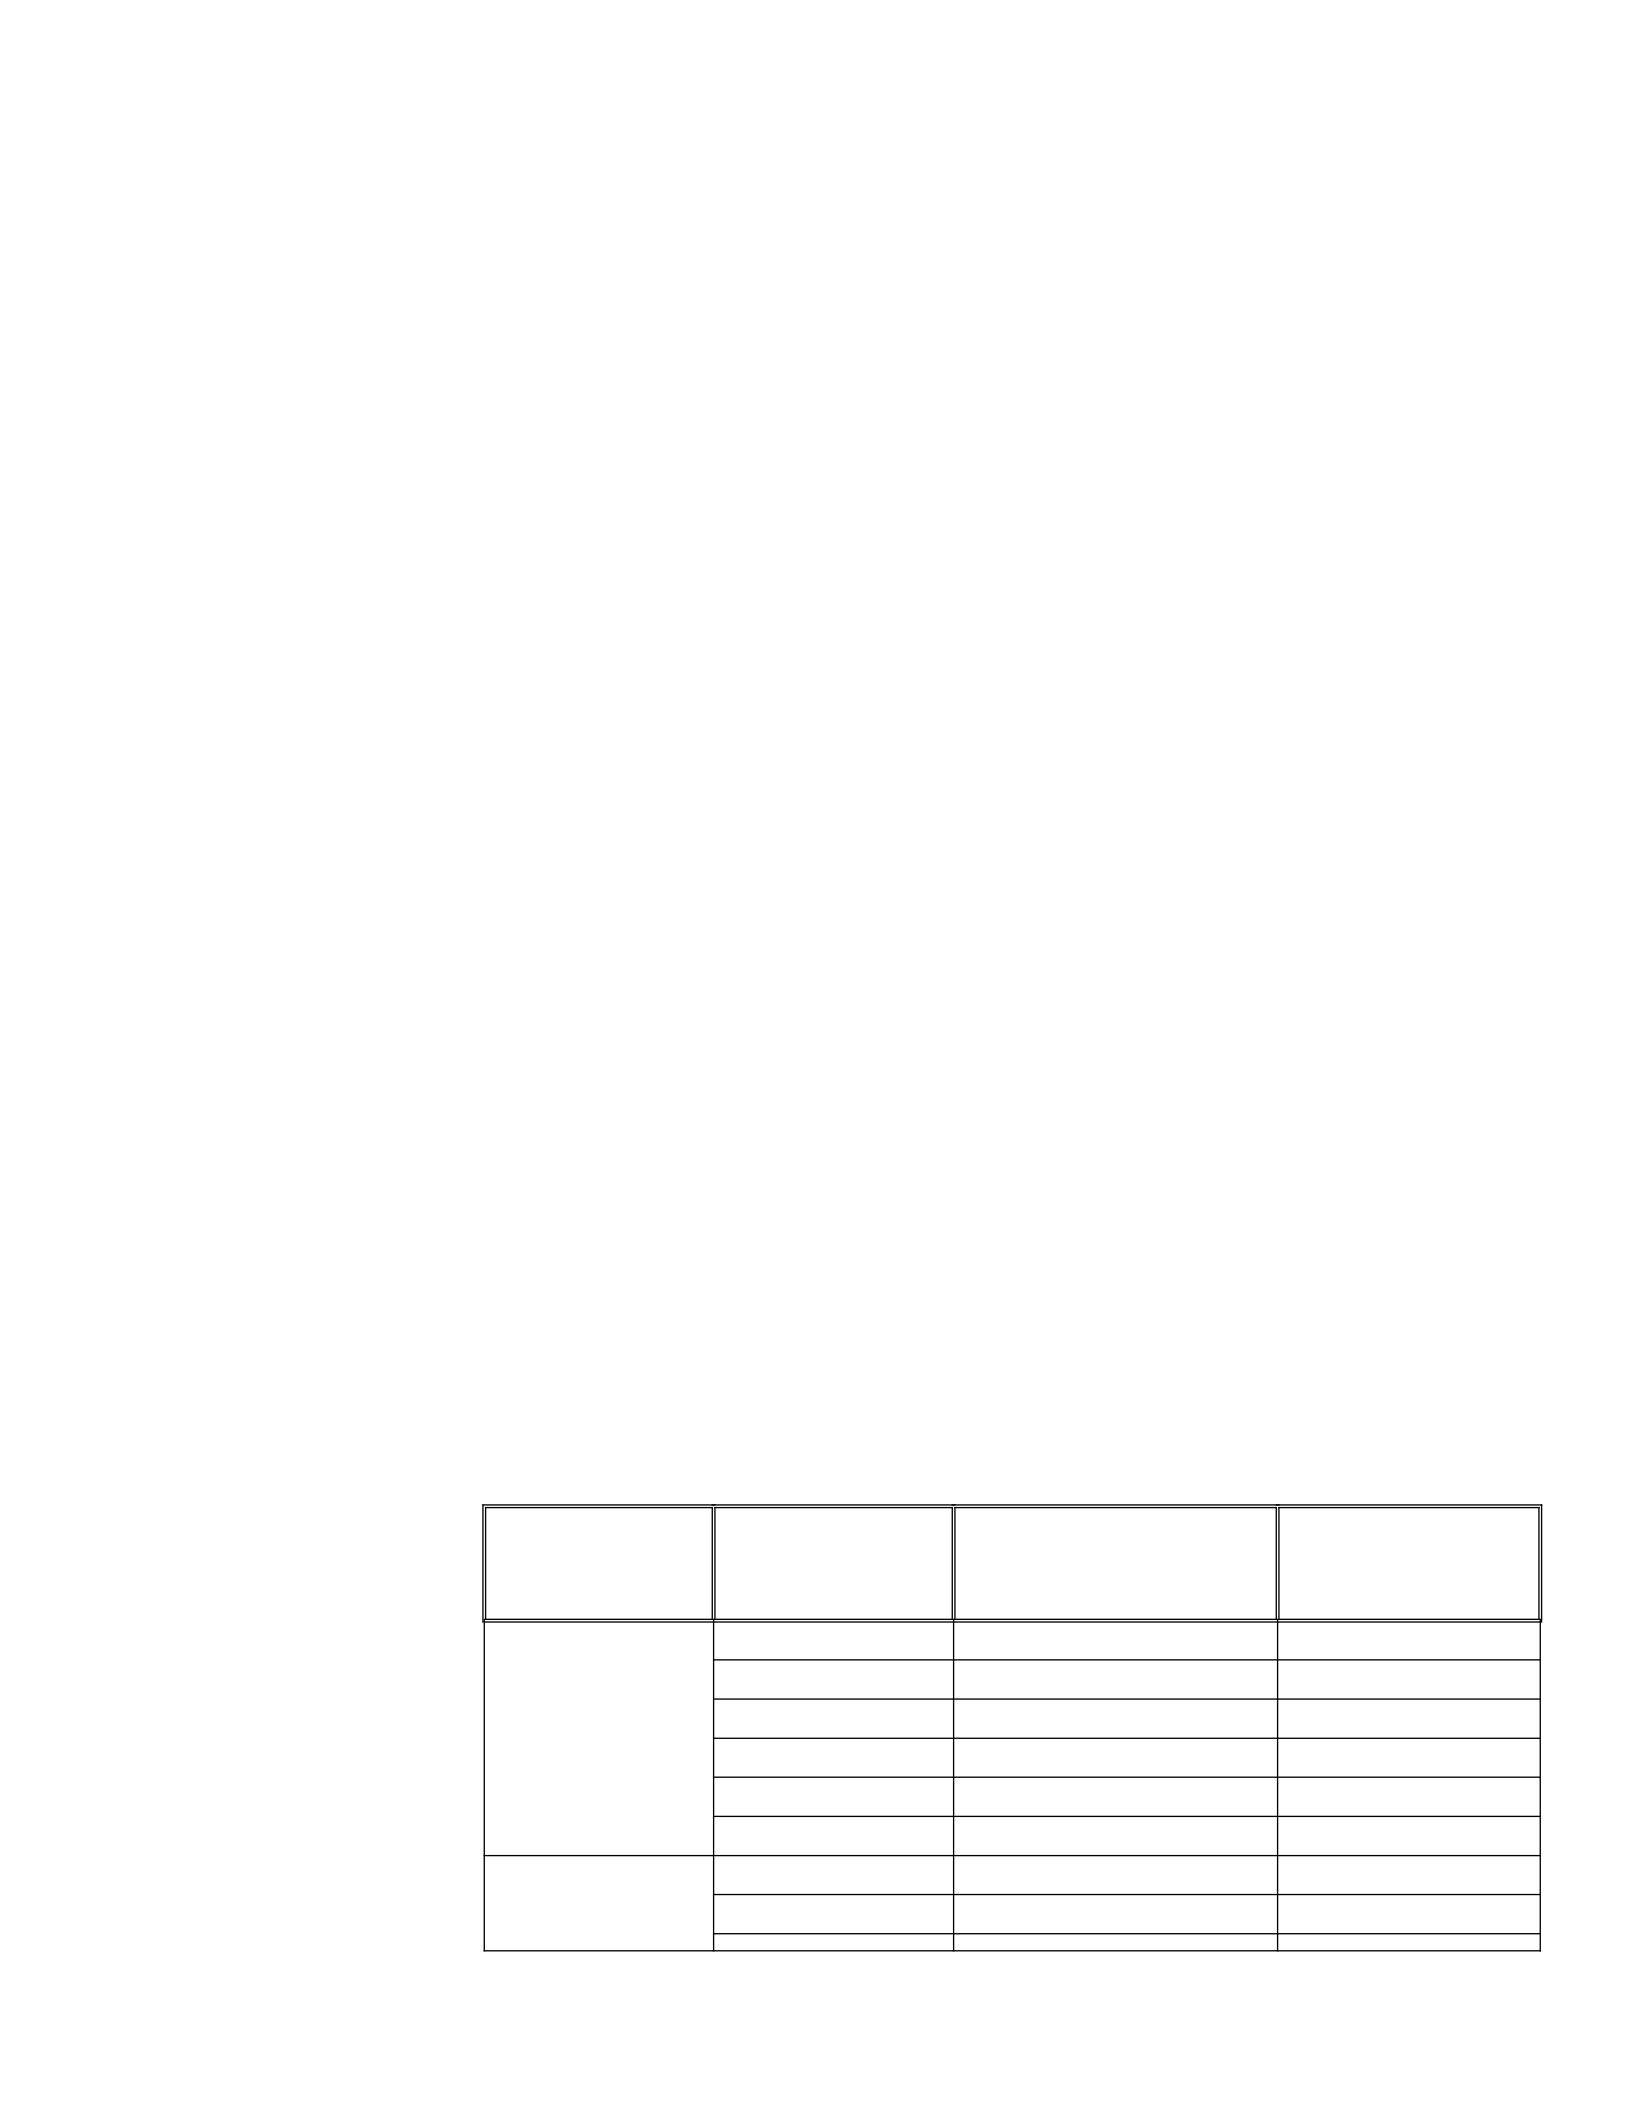
51
simulating a full compliment of passengers or a large internal cargo load, 4500
lbs. of internal weights are used.
The results are presented graphically on Figures A-20 and A-21, and depict
the wind conditions above the tested deck (wind velocity and azimuth),
respectively, and the recommended day and night launches and recovery wind
envelopes, for each approach used. In addition, layered on the plot are the Day
and Night Public Launch and the Recovery Wind Sheath for the T-AFS class
ships.
A total of 265 launch and recovery evolutions were carried out, 130 of which
were port launches and recoveries (100 noon and 30 p.m.), and 135 of which were
right launches and recoveries (109 noon and 26 p.m.). Almost all of the launch
and recovery evolutions carried out are documented as satisfactory and are rated
PRS-1 or PRS-2. Ten evolutions (4% of the total number performed) were
documented as unsatisfactory with the PRS-3 ranking. The wind conditions on
deck and the event numbers of this unsatisfactory evolution are detailed below in
Table 9.
Overall pilot workload evaluated during launch and right recovery Table 9:
Unsatisfactory Evolution Above USNS CONCORD (T AFS 5)
Type
Approach
Launch or
Recovery
WOD (Azimuth
and Velocity)
Conditions
Event Number
(see Table B-9)
Right
Slide 040R at 33 knots 176 and 180
Recovery 045R at 33 knots 179
Recovery 045R at 28 knots 183
Recovery 045R at 22 knots 185
Recovery 330R at 25 knots 201
Recovery 000R at 37 knots 224
Port
Slide 300R at 19 knots 210
Slide 300R at 14 knots 214
Recovery 300R at 13 knots 215

52
evolution, with relative winds between 040 and 045, and between 22 and 33 knots.
During recovery, as the aircraft switches to hovering above the ground, the tendency of
the aircraft is to evaporate rapidly to the right (most likely due to the effects of weather
propellers and the increased power required). A large left pedal input (11/2 to 2") is
required to maintain the aircraft's direction with an upline from right to port, and the
remaining left pedal travel is about 10-12% (PRS-3 is set). In one example (event 185),
during this large left pedal input, the left pedal stop is contacted momentarily (0% of the
left pedal remains), although the tail rotor authority is not visibly decreasing. During
launch, under the same environmental conditions, the aircraft experienced a rapid 10 to
20 right yaw, without command, toward the relative wind line immediately after
crossing the edge of the deck (again, most likely due to the weathervaning effect).
Another large left pedal input (11/2 to 2") is required to hold the yaw rate and set the
aircraft heading in the direction of flight. The remaining left pedal travel is about 14%
(PRS-3 set). Also noted during the launch, was the slight difficulty maintaining altitude
on departure, most likely due to the loss of wind effects as the aircraft transitioned to the
downwind side of the superstructure. To withstand the loss of altitude, a large collective
of 1/2 to 1" up (maximum torque recorded is 121%) is required to withstand the rate of
descent. The tendency of the aircraft to settle on the transition to forward flight at about
the same time as the yaw trip occurs further increases the pilot's workload on the
transition due to the increased torque as the left and upper collective pedals must be
carefully managed to prevent over-torque situations. Next

53
The pedals and collective requirements mentioned above (recorded during launch
and recovery) are recorded at the lower end of the test gross weight range (i.e. just
before refueling). The minimal pedal control margin left in these conditions, the
fast and unpredictable nature of this yaw trip, and the workload associated with
torque management and altitude control during launch and recovery under these
ambient wind conditions, are considered unacceptable by fleet pilots under typical
operating conditions. Because these data points were successfully carried out only
under controlled test conditions, using proven build-up testing techniques, they
were not included in the recommended launch and recovery envelope days for
MH-60S helicopters during the right approach to the AFS-1 T-class ships.
The overall pilot workload was evaluated during the ship's right-hand
recovery, with a relative wind of 330, at 25 knots. During recovery, the aircraft
tends to hover laterally and longitudinally over places with ship movement
(relatively significant at 5 in pitch, 6 in roll), and with moderate cuts
encountered at the short end and above deck (most likely due to airflow
disturbances over the superstructure). The medium cut and fuselage vibration
encountered in the short final and above place both resulted in a VAR-6 rating for
evolution. Maintaining position and getting to that spot is very difficult and
requires lateral and longitudinal cyclic inputs of 1/2 1" 2 3 ,
pedal inputs
1/2" 1 2 . Although this WOD condition resulted in PRS-3, significant
deck movement is considered a major contributor to this unsatisfactory rating.
When other recoveries in identical WOD conditions are attempted PRS-2

54
(event 339), mainly due to much more docile sea conditions, less deck movement,
and less pilot workload. Despite the fact that these WOD conditions, under higher
sea conditions, were considered unacceptable by fleet pilots in operational
conditions, it was included in the recommended day launch and recovery
envelope for MH-60S helicopters during the right approach to the T-AFS 1 class
ships. Its participation was reduced by the assignment of PRS-2 to identical WOD
conditions in more docile marine conditions, and by the restriction of deck
movement on the recommended 3 and 5, respectively.
The overall pilot workload was evaluated during the right launch, with a
relative wind of 000, at 37 knots. During the transition to advanced flight, just
as the aircraft transitions from the flight deck and exits the downwind side of the
superstructure, it exhibits a very strong tendency to yawn right in the direction of
the relative wind. This weathervaning effect is most likely caused by the direct
side forces present on the right side of the fuselage and the tail section after being
cleared of the protective effect (or zero area behind) the superstructure. A large 1
to 2" left pedal input is required to hold the yaw rate (about 30 per second) and
realign the aircraft heading back in the direction of departure (the onset of a rapid
yaw rate results in a 15 to 20 change in the direction of the aircraft, although
almost directly the left pedal input). During a large left pedal input, the left pedal
stop is contacted momentarily (0% of the left pedal remains), although the tail
rotor authority is not visibly decreasing. The minimal pedal control margin left
under these conditions, and the onset of a fast right yaw rate during launch in
these ambient WOD conditions, is considered unacceptable for

55
fleet pilots in typical operational conditions (PRS-3 assigned). Because these data
points were successfully conducted only under controlled test conditions, using
proven build-up testing techniques, these data points were not included in the
recommended day launch and recovery envelope for the MH-60S helicopter
during the right approach to the AFS-1 T-class ships.
The overall pilot workload was evaluated during the port launch, with a
relative wind of 300, at 19 knots. Maintaining altitude, while hovering over the
ground, before switching to forward flight, is difficult, mainly due to the ship's
deck movement (3 pitch, 5 roll), and requires a large and fast collective input
from 1 2" 1 Hz. The workload is further increased by the requirement to
closely monitor and manage engine torque, which is recorded as high as 128% for
1 second. Maintaining the direction of the head, while hovering over the place is
also difficult, especially due to the continuous moderate turbulence and yaw chop,
which requires pedal input
1/2" 1 2 . The high workload associated with maintaining position and
direction while hovering over the place, prior to the transition to advanced flight,
is considered unacceptable by fleet pilots under typical operational conditions
(assigned PRS-3). Because these data points were successfully conducted only
under controlled test conditions, using proven build-up testing techniques, these
data points were not included in the recommended launch and recovery days for
MH-60S helicopters during the T-AFS1 class port-to-ship approach.
The overall pilot workload was evaluated during launch and port recovery,
with relative winds of 300, between 13 and 14 knots. During recovery, while
still in a long final stage, the slope of the slide and the level of closure are difficult

56
to manage, because The strong effect of the tail wind is a quarter of the relative
port. In addition, the maintenance of position and direction, while hovering above
the deck before landing, is noted difficult, with unpredictable travel on all axes
and continuous moderate turbulence. The overall workload required while
hovering includes 1" 2 3 , lateral and longitudinal cyclic inputs at to Hz and
1/2" 1 2 . pedal inputs at to Hz During launch, on the transition to advanced
flight, the aircraft evaporates rapidly to the right (15 to 25), and begins to lose
altitude. The large right yaw, most likely caused by the momentary loss of tail
rotor effectiveness, requires a large left pedal input (1 to 2") to hold the pace and
return the aircraft to the direction of flight. The loss of altitude is only captured
with a large collective input (1-2") upwards. It is thought that this loss of altitude
is most likely due to the transition from the effect on the ground to the OGE
condition and the loss of wind effects experienced during the transition to the
downwind side of the superstructure (and the associated increase in power
required for each). The high workload associated with maintaining position and
direction while hovering over the place and during the transition to advanced
flight was considered unacceptable by fleet pilots under typical operational
conditions (PRS-3 was commissioned). Because these data points were
successfully conducted only under controlled test conditions, using proven build-
up testing techniques, these data points were not included in the recommended
launch and recovery days for MH-60S helicopters during the AFS-1 T-class ship-
to-port approach.
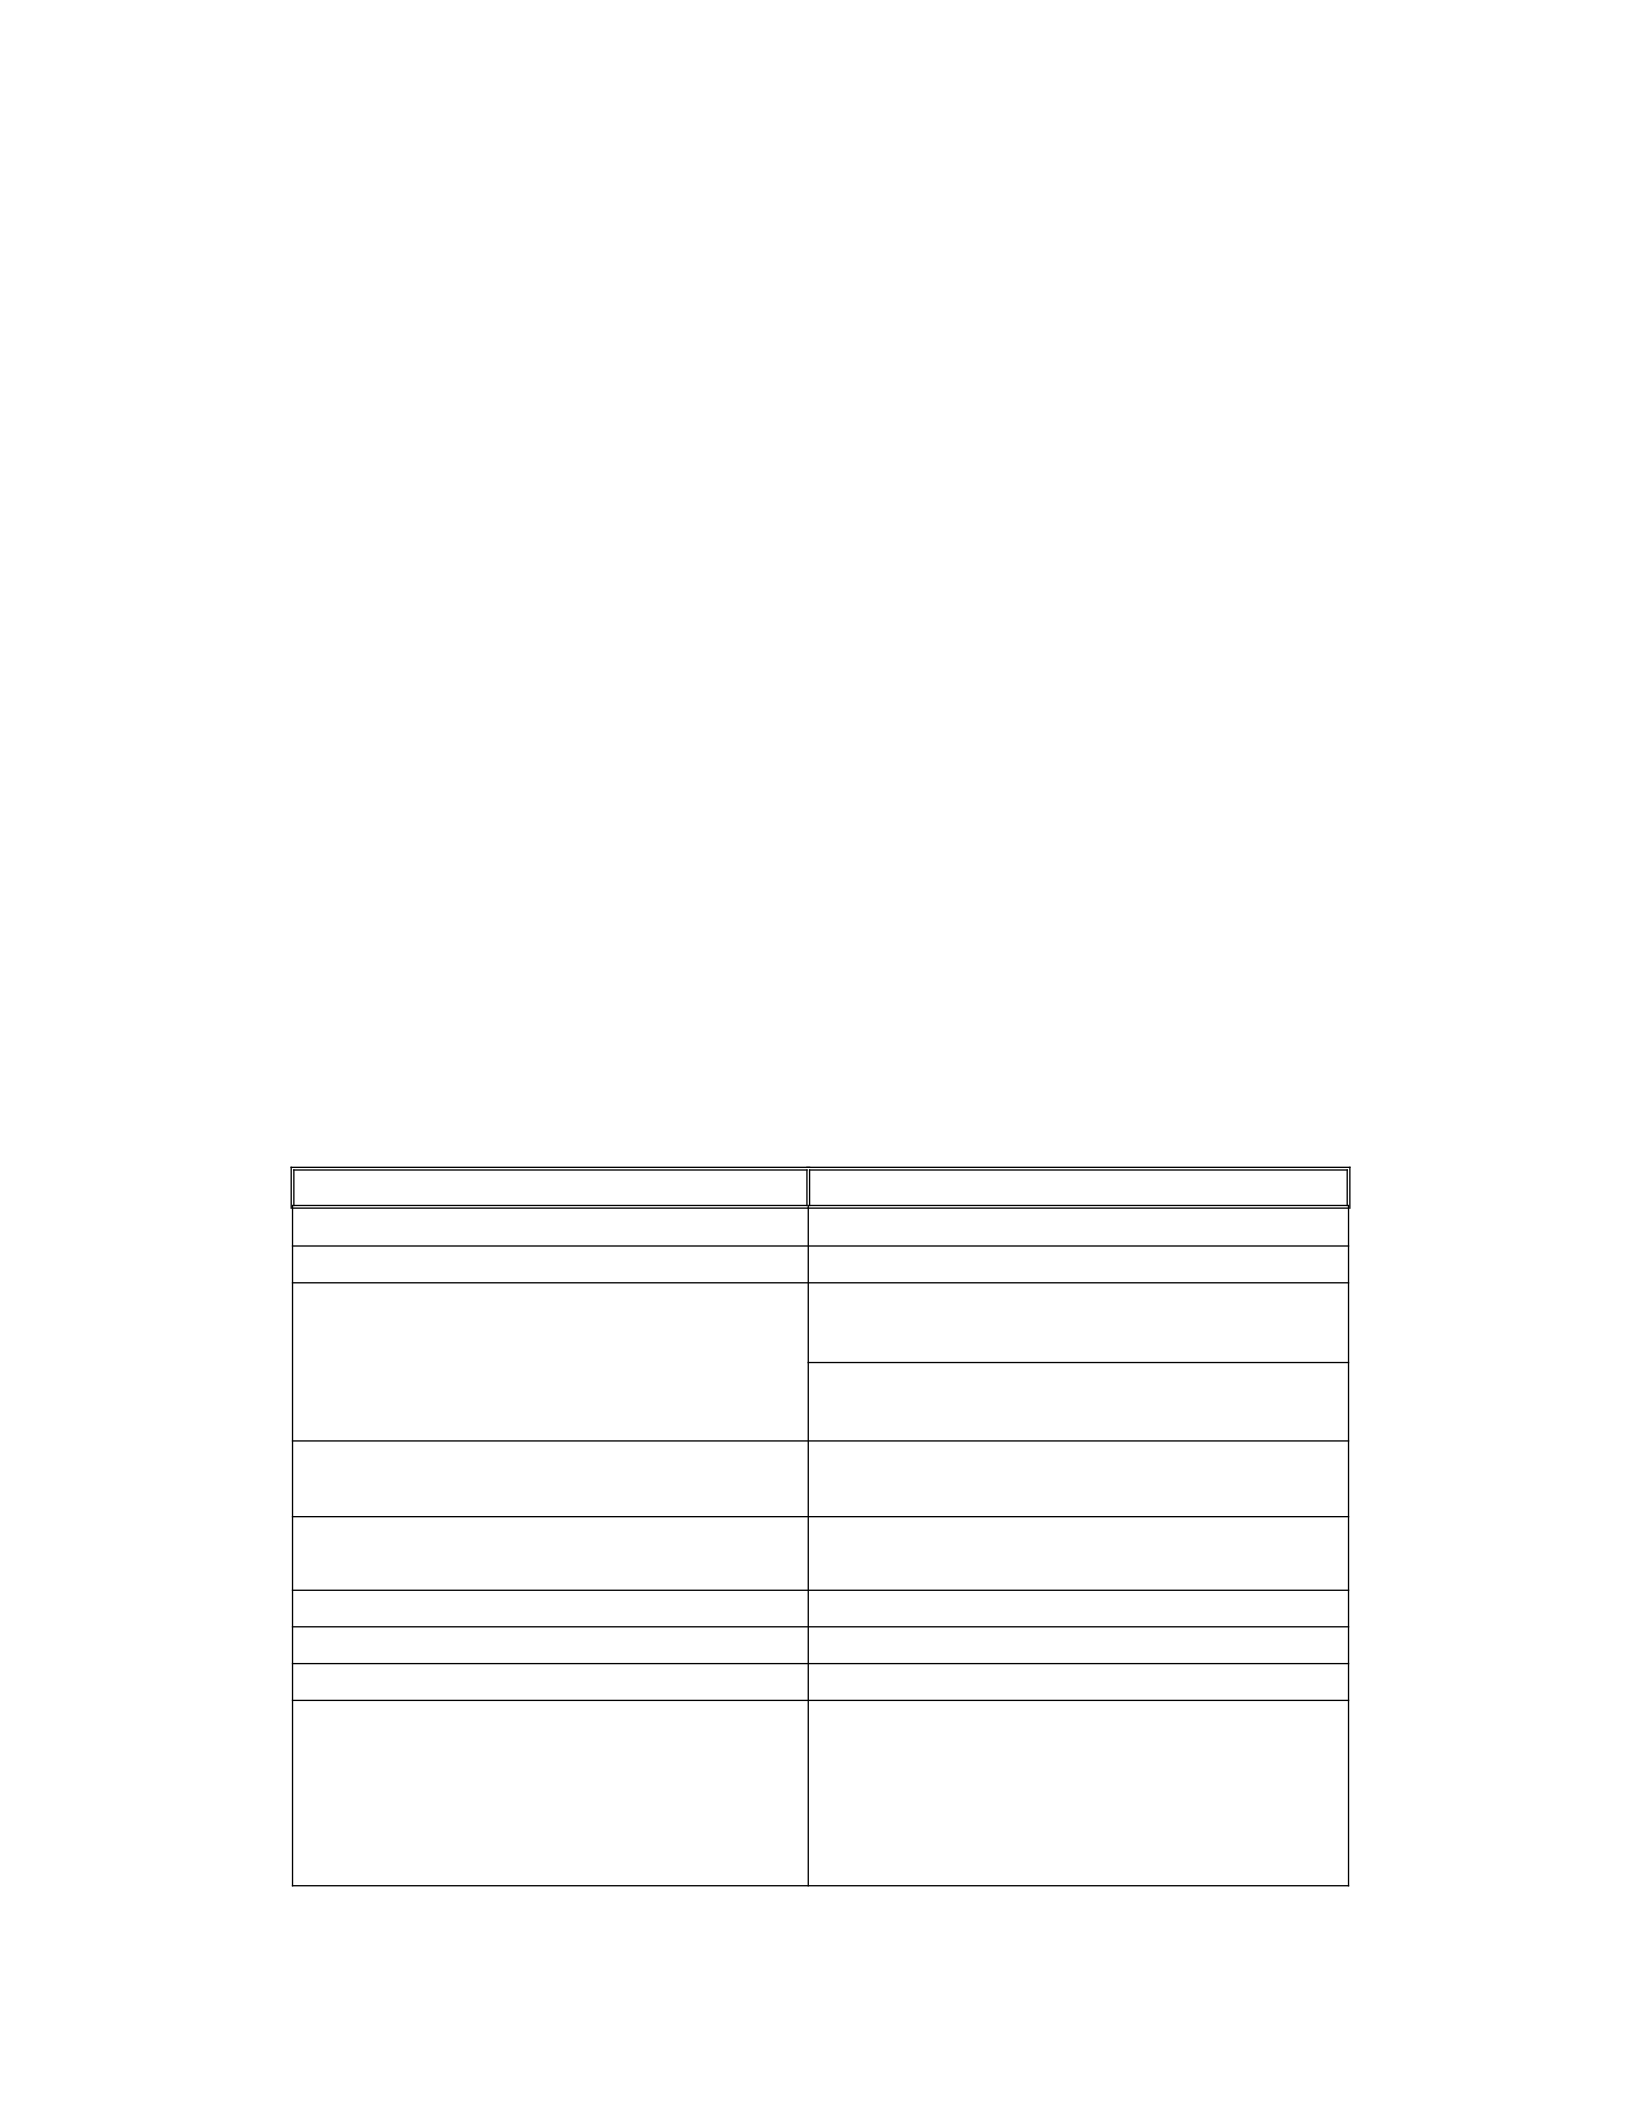
57
iii. USNS SIRIUS (T-AFS 8)
Daytime launches and the development of the recovery wind cover were
carried out aboard the ship USNS SIRIUS (T-AFS 8) during the port approach
and right to and from the deck of the ship. The conditions and configurations of
the test days are presented below in Table 10.
The test was carried out on a relatively high gross weight of 21750 lbs. To
achieve the gross weight of this mission representative aircraft, simulating a full
complement of passengers or a large load of internal cargo, 4880 lbs. of internal
weights are used.
The results are presented graphically on Figures A-22 and A-23, and depict the
wind conditions above the tested deck (wind velocity and azimuth), respectively,
and the recommended day and night launches and recovery wind envelopes, for
Table 10: Conditions and Configuration of USNS SIRIUS Test Day (T-AFS 8)
Parameter Condition/Configuration
Outdoor Air Temperature Range 14 to 16 Celsius
Pressure Height Range –70 to -40 feet
Sea Country
0 to 2 of ship pitch (average
0)
0 to 2 ship rolls (0 average)
Wind-Over-Deck Condition Tested
(relative to the bow of the ship)
2 to 27 knots, around the entire azimuth
of the wind 360
Gross Weight Range of Aircraft 22250 to 21250 lbs. (4880 lbs. of
internal weights are used)
Aircraft Center of Gravity Range 356.4 to 353.4 inches
Target Gross Weight 21750 lbs.
Rotor Speed 100%
Automatic Flight Control System
Configuration
Stabilizer in automatic mode; stability
augmentation, Trim Autopilot
and
Hydraulic pilot help functions
involved.

58
each approach used. In addition, layered on the plot are the Day and Night Public
Launch and the Recovery Wind Sheath for the T-AFS class ships.
A total of 84 launch and recovery evolutions were carried out, 48 of which
were port launches and recoveries, and 36 of which were launches and recoveries
on the right. All of the launch and recovery evolutions carried out are documented
as satisfactory and are rated PRS-1 or PRS-2. The test attempt aboard the USNS
SIRIUS (T-AFS 8) was hampered by several problems, the most prominent of
which was the destruction of one of the hangar doors, which soiled the flight deck
and forced an unexpected diversion to the coast, and resulted in the premature
termination of the T-AFS 8 test attempt. In addition, instrumentation problems
hinder the collection of useful tail rotor impression pitch data, via telemetry, at
higher gross weights. In the end, the testing effort originally designed to evaluate
the operation of the higher MH-60S gross heavy ship was abruptly terminated
with minimum daytime wind cover data, and prior to the collection of night wind
cover development data. The development of the limited-day windscreen
achieved occurred during a single test evolution aboard the USNS SIRIUS (T-
AFS 8).
Power requirements, and associated pilot workload during fuselage torsional
limit maintenance, are evaluated during launch and port recovery, with relative
tailwinds (Table B-10, events 77, 78, 82, 83, 86, and 87). No unsatisfactory
handling quality issues were identified, and all ratings were PRS-1 or PRS-2.
However, torque management is documented as the highest workload task, mainly
due to the 15 to 20% increase in torque above
59
IGE hover power is required to prevent settling below the edge of the deck, and to
achieve a satisfactory climb after launch.
4. PILOT-VEHICLE INTERFACE
i. Common
Throughout the development of the launch and recovery wind envelope for the
MH-60S aboard various classes of ships, several deficiencies of the pilot vehicle
interface (PVI) were identified relating to the evaluation of the helicopter on
board and the effects of the relative wind on the deck of the helicopter. Each of
the identified deficiencies negatively contributes to the pilot's workload required
during the ship's launch and recovery operations, and, as such, plays some role in
the final definition of the launch and recovery wind envelope.
ii. Front View Field
The front field of view (FOV) is evaluated in both static and dynamic
environments. Static evaluation is carried out on the ground, no hydraulic or
electric power is applied, and the rotor does not rotate. The azimuth and elevation
of the cockpit structure and components that obstruct the pilot's front field of view
(right seat), from the approximate position of the design eye, are documented (in
degrees). The results are presented directly in Figure A-24. The main front field of
view, from the pilot position, is documented extending from about 38 center left
to 46 center right, and 21 above center and 29 below center. Significant field
of view barriers from this position are glare shields and instrument panels, as well
as the airframe structure between the

60
instrument panel and right door (to include door hinge support, separating the
pilot windshield and pilot door window).
The forward field of view of the pilot and copilot stations was quantitatively
evaluated in a dynamic environment during the launch and development of the
recovery wind envelope aboard USS BATAAN (LHD 5), USNS CONCORD (T-
AFS 5), and USNS
SIRIUS (T-AFS 8). The conditions and configurations of the test days are
presented below in Table 11.
During almost all approaches to the ship's deck for landing, with the pilot
sitting at a comfortable eye height position, the field of view was inadequate and
unsatisfactory, and limited visibility of the landing environment. Especially
during flight slowdowns, when the nose attitude up to 15 is not uncommon to
safely control the degree of closure before landing, the field of view is severely
limited by instrument panels and glare guards.
61
Table 11: Conditions and Configuration of PVI Evaluation Test Days
Parameter Condition/Configuration
Outdoor Air Temperature Range 15 to 30 Celsius
Pressure Height Range –150 to 220 feet
Sea Country 0 to 6 of ship pitch (average 1)
0 to 10 boat rolls (average 2)
Wind-Over-Deck Condition
Tested (relative to bow
ship)
1 to 45 knots, around the entire azimuth of the
wind 360
Gross Weight Range of Aircraft 22250 to 20582 lbs. (4500 & 4880 lbs.
internal weights used)
Aircraft Navel Arabic
Gravitasi
Range
363.4 to 352.9 inches
Target Gross Weight 21750 & 21000 lbs.
Rotor Speed 100%
Automatic Flight Control
System Configuration
Stabilizer at automatic mood; Stability
The augmentation, trim, autopilot, and
hydraulic pilot assist functions are activated.

62
During this approach, in most cases, at least a small pedal input is required to
evaporate the aircraft from the direction of flight (usually 10 to 30 right or left,
depending on the pilot's seat in the controls), in order to prevent visual loss of the
landing environment (landing site, superstructure, line up line or landing
signalman enlisted (LSE)). By yawning the aircraft slightly from the direction of
flight, the pilot was able to maintain a line of sight to the ship's deck through the
bottom of the windshield and chin bubbles (no longer obstructed by glare guards
and instrument panels). Just before the transition to hover over the flight deck, and
with the application of the power required to hover, the pilot was required to
release the pedal inputs necessary to maintain an adequate field of view on the
final approach, in order to align the nose of the aircraft with the line up line for
landing.
Inadequate field of view, due to instrument panels and glare protective
barriers, during the final approach to the ship's deck for landing, is very limited
and unsafe, and often results in loss of visibility of the landing environment.
These shortcomings directly affected the pilot's workload and associated
workload ratings during most of the ship's testing.
iii. Cockpit Vibration
Cockpit vibrations were qualitatively evaluated during the launch and
development of the recovery wind envelope aboard the USS BATAAN (LHD 5),
USNS CONCORD (T-AFS 5), and USNS SIRIUS (T-AFS 8). The conditions and
configurations of the test days are presented above in Table 11.

63
Excessive levels of cockpit vibration (VAR set 5, 6, and 7) are documented
during almost all flights in a low airspeed regime. These medium to heavy cockpit
vibrations consist primarily of four per revolution, the main rotor vibrations
documented almost continuously at air speeds of less than 40 to 50 KIAS, and
especially during deceleration and the onset of main rotor vortex consumption. In
some cases, the cabin vibration dampers are completely saturated and
subsequently incapable of absorbing vibrations, which is indicated by their
excessive travel and their contact with the fuselage around the mounts (visually
and aural observed by the cabin crew). In addition, operations at higher gross
weights tend to exacerbate vibrations, and cause them to occur earlier, with
respect to airspeed. MH-60S helicopters are required to operate extensively in a
low-airspeed regime while operating in and around naval vessels, especially
during launch and recovery, and VERTREP operations. The low airspeed
environment is one of the most critical and demanding during flight operations on
ships, and the excessive and continuous levels of main rotor vibration experienced
in the cockpit during most of the development of this wind envelope are
exhausting, annoying, and annoying. It is recognized that most missions are not
flown exclusively in this low-airspeed regime (although about 50-75% of
VERTREP missions can). However, all flights end up in this regime, when pilots
are most tired and consequently, most adversely affected by this high level of
vibration. This
shortcoming directly affects pilot workloads and related workload ratings during
most of the ship testing.
64
iv. Tail Wheel Location
The location of the Tail Wheel was qualitatively evaluated during the launch
and development of the recovery wind cover aboard the USS BATAAN (LHD 5),
USNS CONCORD (T-AFS 5), and USNS SIRIUS (T-AFS 8). The conditions and
configurations of the test days are presented above in Table 11.
There is no statistically documented significant tail wheel location with
respect to the helicopter's "footprints" while on the deck of the ship with the main
mount at the front of the main mount circle.4 In other words, the helicopter fit on
each of the decks of the evaluated ship was satisfactory and did not contribute to a
significant increase in pilot workload during the ship's operation.
Specifically, above the USS BATAAN (LHD 5) the location of the tail wheels
or footprints during the landing is not documented as unsatisfactory or lacking in
any way because the main mount circle is not used on the ship due to the large
size of the flight deck. Above the USNS CONCORD (T-AFS 5), about 52 feet of
line lines are available behind the front half of the main mount circle, which easily
accommodates the 29-foot longitudinal wheelbase of the MH-60S, and does not
result in an increase in the pilot's workload during deck landing. Lastly, above the
USNS SIRIUS (T-AFS 8), which has a much shorter lineup
4 The "trail" of the helicopter is determined by the lateral distance between the leftmost and
rightmost main mounts, and by the longitudinal distance between the frontmost and rearmost
wheels. This distance is used to determine the static physical fit on a particular ship's deck and in
the analysis of the strength of the associated deck. The main mount circle, designed to provide the
pilot reference during landing, ensures that the tail wheels will land safely on the deck of the ship
provided that the main mount lands at the front of the main mounting circle, and the helicopter is
parallel to one of the line lines.
65
available behind the front of the main mounting circle (about 38 feet), the MH-
60S's longitudinal wheelbase was still satisfactorily accommodated during deck
landing. It should be noted that the smaller flight deck and the increased precision
required during landing are associated with a slightly higher pilot workload while
on the deck of the ship, just before landing. However, this slightly higher pilot
workload is not significant enough to result in unsatisfactory handling quality
(PRS-3 or greater).
What has been documented as significant during ship operations with respect
to the location of the tail wheels, is its frequent proximity to the ship's deck during
the final approach to landing. Due to the upward nose attitude required for the
maintenance of deceleration and the closing rate on the final approach, the
proximity of the tail wheel to the ship's structure, deck personnel or gradual load
must be managed with great care.5 Tail winds or higher approach speeds, and/or
the throwing deck of the vessel, typically result in the greatest upward nose
attitude at the short end and the smallest tail wheel clearance height above deck
(and an increase in pilot workload due to increased workload requirements for tail
wheel height management).
Finally, and most importantly during the transition on the deck of the ship, is
the fact that the tail wheels are structurally designed with large shock absorbers to
absorb large loads longitudinally, rather than laterally. Due to the unsatisfactory
field of view (and the pilot-initiated yaw needed to fix it) above the T-AFS class
The 5 hover steady state on MH-60S requires about 5 nose up attitude (i.e. when the nose of
the aircraft is about 10 feet AGL, the tail wheels are about 5 feet AGL). The slowing attitude (nose
up) worsens the physical characteristics of this fuselage and demands careful high management of
the tail wheels especially when crossing the edge of the deck to land.

66
ship, and to the left pedal 45 turns required at the transition to hovering over
LHD-class ships, lateral translation of the aircraft and, thus, the tail boom, are
common. If a strong contact in the lateral direction is made with the stationary
structure of the ship, there is a potential for separation of the tail wheels.
The location of the tail wheel behind the fuselage, the requirement for an
excessive nose-up attitude during deceleration, and the consequent very limited
field of view and loss of situational awareness with respect to the ship's deck
environment, directly affected the pilot's workload and associated workload
ratings during most of the ship's testing.
v. Down Wash Main Rotor
The effects of major rotor washout on the ship's deck environment (ship
structure, deck personnel and equipment) were qualitatively evaluated during the
launch and development of the recovery wind envelope aboard the USS
BATAAN (LHD 5), USNS CONCORD (T-AFS 5), and USNS SIRIUS (T-AFS
8). Test day
The conditions and configurations are presented above in Table 11.
In general, the effect of the underwash of the single main rotor on the ship's
deck environment is more severe than that typical of the H-46D tandem helicopter
when conducting similar ship operations (launch and recovery, VERTREP, etc.).
This is most likely due to differences in the loading of the main rotor discs,
resulting in the resulting differences in the speed induced at the rotor head and the
difference in the bottom wash speed experienced by flight deck personnel.
67
Flight deck personnel can experience washout speeds up to about 30% higher than
those of the MH-60S than those of the H-46 (with the same gross weight).6
This high washout speed was particularly significant during tail wind launches
and the development of recovery wind shrouds on board T-AFS class ships.
During tail wind launches and recovery wind shroud development, especially
at higher aircraft gross weights (above 21000 lbs.), relative rear-to-front WOD
conditions tend to push the main rotors down washing forward across the flight
deck toward the hangar and into the flight deck personnel (especially the LSE
standing directly in front of the hangar door, and the rest of the support personnel
standing on the catwalk around the hangar).7 In addition, this forward-driven rotor
wash tends to roll up the hangar surface and back to the helicopter and flight deck,
lingering in the deck environment longer than usual without the typical forward-
to-backward WOD conditions available to clean the flight deck of such
turbulence. The net result is an increase in pilot workload while maintaining an
above-deck position and compensating for the associated turbulence
6 The disc loading on each 21000 lbs. hovering H-46 helicopter rotor head is approximately 5
lbs./ft2 (at sea level, assuming that thrust equals weight and that thrust is divided evenly between
the two rotor heads (which is not entirely accurate)). The disc loading on the 21000 lbs. hovering
MH-60S rotor head is about 9 lbs./ft2 (again, at sea level and assuming that thrust equals weight).
The induction speed at the rotor head required to produce 21000 lbs. thrust is about 30 and 22
mph, and the actual downward wash speed observed by flight deck personnel may actually be as
high as 60 and 44 mph, respectively for MH-60S and H-46. "Disc loading above 10 to 12 lbs./ft2
can explode... equipment and personnel." (Prouty, 1985)
The 7 LSE typically stands in front of the helicopter, facing backwards with respect to the ship,
and provides position guidance to the pilot through hand gestures during launch and recovery
operations. On board the LHD-class ships, the LSE stands far in front of and to the right side of
the landing site. However, on board the T-AFS class ships, LSE was forced to stand between the
helicopter and the hangar surface in the line of line used by the pilots. Especially on board T-AFS
8 class ships, the distance between the LSE and the helicopter is not very large, and thus the
downward washout effect can be significant.

68
by re-engulfing the main rotor from the surface of the hangar. In addition, an
increase in workload was observed for flight deck personnel supporting flight
operations as they attempted to cope with the effects of this high gross weight
main rotor wash. On several occasions, as the plane hovered above deck, LSE was
pushed back and forced to the hangar door which then provided the necessary
support for him to continue his signaling duties.
The apparent significance of the rotor wash effect on the ship's deck
environment and the workload in the cockpit was observed during the last launch
and recovery wind envelope test event aboard the USNS SIRIUS (T-AFS 8) (see
table B-10, events 80-87). All of these data points are rated PRS-2, however, the
associated pilot workload is almost exclusively due to flight deck turbulence
(VAR-6) and the resulting power management and position maintenance
difficulties. Of particular interest is event 87 (Table B-10). While hovering over
the deck just before takeoff, the downward rotor flows into the hangar space
through the partially open central hangar door, and back out through the closed
right hangar door, tearing it off its path. Due to the nature of the hangar door
failure, and the inability to secure it from complete failure and separation during
subsequent landings, the development of the wind shroud was completed
prematurely and the helicopter was forced to be transferred to Norfolk Naval
Station, Virginia.
The MH-60S's high disc loading at high gross weight, and the high speed
resulting from the downward rotor washing, is significant, especially during
tailwind operations. Ground personnel are forced to concentrate on protection
often
69
themselves from the bottom wash than on their essential flight deck duties; the
pilot's workload increases with the increased turbulence experienced when
operating near the ship's superstructure; and severe damage to the hangar
equipment is caused.
5. SLIDE AND RECOVERY WIND ENVELOPE DEVELOPMENT
PROCESS
During the investigation of the effects of relative wind above deck on the MH-
60S helicopter during initial onboard testing, deficiencies were documented in the
common process that the U.S. Navy currently uses in the development of
helicopter launches and wind envelope recovery.
Most importantly, is the fact that the initial MH-60S test attempts did not
satisfactorily make use of the vast amount of knowledge pertaining to such efforts
that currently exist in governments, military, civilians and academic institutions
around the world. In particular, this testing effort did not use any comparative
studies with previous H-60 ship test data, nor did it use any prediction tools for
aerial aerodynamic modeling of ships and helicopters. As a result, a lot of time
was spent carefully exploring wind conditions on a deck that had previously been
explored (or at least partially explored). Also, a lot of time is spent carefully
exploring unknown or unpredictable wind conditions on deck that may have been
predicted and planned in advance.
In addition, initial testing efforts were severely limited by the ambient
conditions available during the testing period at sea, resulting in a shroud that
limited operational flexibility not because the aircraft's handling quality
guaranteed it, but

70
Due to adequate environmental conditions there is no way to find the limitations
of the actual handling quality of the ship from the fuselage. During all launch and
recovery wind envelope development trial periods, ambient conditions (i.e. not
enough ambient wind is available when needed) and time constraints (imposed by
the operational commitments of the test vessel schedule) always hinder the
development of the launch and recovery wind envelope as much as possible. In
other words, documentation of unsatisfactory aircraft handling quality does not
play a major role in the definition of the recommended launch and final recovery
wind envelope. In fact, in all cases, that definition is almost entirely due to
inadequate ambient wind speed and/or insufficient time available (to maximize
the use of available winds, or to wait/seek adequate wind) to develop the widest
possible wind cover.
71
IV. CONCLUSION
1. COMMON
Overall, investigations of the effects of the relative wind on deck on MH-60S
show that the helicopter possesses the handling qualities necessary to operate
safely in the ship's environment during launch and recovery operations from LHD
1, T-AFS 1, and T-AFS 8 class naval vessels. Quite satisfactory handling quality
data were collected during this investigation to develop a relatively large and
operationally flexible launch and recovery wind shield over three different classes
of naval vessels for daily operations. Only aboard the relatively large and
operationally flexible USNS Concord (T-AFS 1 class) for night operations was
developed.
This envelope is a measurable result of a rather qualitative investigation of the
effects of wind above deck on the MH-60S helicopter during launch and recovery.
They only cover wind conditions above deck that are actually tested and which,
based on the subjective opinion of the qualified test pilots involved, will allow for
safe launch and recovery operations for the average MH-60S fleet pilot. Only a
small number (<2%) of the above-deck wind conditions tested resulted in
unsatisfactory handling quality, and these conditions, naturally, were excluded
from the recommended launch and recovery wind envelopes.
72
In addition, this investigation produced some unsatisfactory findings related to
the operation of these helicopters on board, which, even if carried out within the
wind cover recommended above, adversely affected an already dangerous
operation. In particular, this unsatisfactory pilot-vehicle interface (PVI) problem
was found to contribute significantly to the pilot's workload associated with
launch and recovery operations on board during the investigation of the effects of
wind on deck on these helicopters.
2. LAUNCH AND RECOVERY OF WIND ENVELOPE DEVELOPMENT
i. USS BATAAN (LHD 5)
The day launch and recovery wind envelope developed during the
investigation of the effects of relative winds over the deck of MH-60S helicopters
while operating aboard the USS BATAAN (LHD-5) were deemed satisfactory for
the use of the operational fleet aboard all LHD-1 class ships. This envelope,
presented in Figures A-16 through A-19, provides sufficient initial operational
flexibility for fleet use and should allow for consistently safe ship launch and
recovery operations using points 4, 5, 6 and 7, at or below 21500 lbs of aircraft
gross weight.
Because the effects of the relative winds above deck during daytime launches
and the development of recovery wind envelopes were not investigated for the
remaining points (1, 2, 3, 8, or 9), all-day launch and recovery operations aboard
LHD-1-class vessels using these points should be carried out within a day of
General Launch and Recovery Wind Envelopes for LHD-class ships (Figure A-8).

73
Similarly, since the effects of relative winds above deck during night launches
and the development of recovery wind shrouds are not investigated at all (in the
case of points 1, 2, 3, 8, or 9) or beyond the night of the Public Launch and
Recovery Wind Shroud for LHD-class vessels (in the case of points 4, 5, 6, or 7),
all-night launch and recovery operations must be carried out within this night's
public shroud.
It should be noted that the use of day or night public launches and recovery
wind shields on board the ships where MH-60S is expected to be deployed for an
extended period of time is unsatisfactory. This common envelope imposes severe
operational limitations not only on MH-60S, but also on the LHDs where it is
deployed, and on the entire Amphibious Ready Group (ARG) of which it is an
important part. Operating with such a limited launch and recovery wind envelope
would require the LHD to direct a very specific course during amphibious
operations for an extended period of time (to launch and recover their MH-60S
amphibious search and rescue assets). This not only makes the entire ARG more
vulnerable, but also limits the operational flexibility and maneuverability of the
LHD and its airwing, as both are inherently limited to the most stringent launch
and recovery shroud requirements of a wide range of airwing aircraft.
ii. USNS CONCORD (T-AFS 5)
The day and night launches and recovery wind envelopes developed during the
investigation of the relative wind effects over the deck of the MH-60S helicopter
while operating over the USNS CONCORD (T-AFS 5) were deemed satisfactory
for the use of the operational fleet aboard all T-AFS 1 class ships.

74
These envelopes, presented in Figures A-20 and A-21, provide sufficient initial
operational flexibility for fleet use and should allow for consistent safe ship
launch and recovery operations, using a port or right approach, at an aircraft gross
weight at or below 21500 lbs.
iii. USNS SIRIUS (T-AFS 8)
The day launch and recovery wind envelope developed during the
investigation of the relative wind effects over the deck of the MH-60S helicopter
while operating over the USNS SIRIUS (T-AFS 8) were considered satisfactory
for the use of the operational fleet aboard all T-AFS 8 class ships. This envelope,
presented in Figures A-22 and A-23, provides sufficient initial operational
flexibility for fleet use and should allow for consistent safe ship launch and
recovery operations, using a port or starboard approach, at or below 21500 lbs of
aircraft gross weight.
Due to the effects of the relative winds above deck during night launches and
the development of the recovery wind sheath were not investigated, due to the
premature and unexpected termination of the test effort, all-night launch and
recovery operations aboard the T-AFS 8 class ships had to be carried out within
the night of the General Launch and Recovery Wind Envelope for the T-AFS
class ships (Figure A-9).
It should be noted that the use of night public launches and recovery wind
shelters on board the ships where MH-60S was expected to be deployed for an
extended period of time was unsatisfactory. This general envelope imposes severe
operational limitations not only on MH-60S, but also on T-AFS on
75
deployed, and throughout the Carrier Battle Group (CBG) which is an important
part. Operating with such a limited wind shield, launch and recovery would
require vessels at CBG to steer very specific paths for long periods of time, while
for ongoing replenishment. This not only makes the entire CBG more vulnerable,
but also limits its operational flexibility and maneuverability, while not needing to
increase the time, effort, and cost required for recharging.
3. PILOT-VEHICLE INTERFACE
i. Common
The pilot-vehicle interface deficiencies observed during these tests all
adversely affected pilot workload associated with ship operations in general, and
were identified as common to ship operations in general, rather than related to
ship operations above a specific ship class.
ii. Front View Field
The field of view (FOV) documented during this investigation was
unsatisfactory, and the pilots of the MH-60S fleet should not be expected to
operate regularly with this severe shortcoming. The FOV available to pilots
flying, especially when slowing down to land, is severely limited and often results
in a loss of visual contact with the landing environment. The presence of unsafe
conditions during such a critical flight phase may result in a collision with the
vessel, deck personnel, or deck equipment.

76
iii. Cockpit Vibration
Excessive and continuous vibration of the main rotor, which is observed in the
cockpit when operating in a low airspeed regime during this time, is
unsatisfactory. The pilots of the MH-60S fleet should not be expected to operate
regularly with this drawback being overwhelming. These vibrations, especially at
higher gross weights, are very tiring, annoying, and annoying when performing
ship recovery. The presence of unsafe conditions during such critical phases of
aviation may result in reduced situational awareness and carelessness during
critical phases of aviation, and may lead to collisions with ships, deck personnel,
or deck equipment.
iv. Tail Wheel Location
The location of the tail wheel behind the fuselage, which was evaluated during
this investigation, required further investigation and consideration for repair
and/or relocation. The current location, along with the consistent requirement for
a large nose attitude during deceleration for landing, and consequently a very
limited field of view and loss of situational awareness with respect to the ship's
deck environment, consistently contributes to an increase in pilot workload. The
increase in pilot workload during recovery is mainly due to the additional
requirements of tail wheel height management. This condition may ultimately
result in contact between the tail wheel and the ship's structure, deck personnel or
deck equipment.
77
v. Down Wash Main Rotor
The high speed of the main rotor down wash observed during this
investigation is significant. Especially on the high gross weight of the aircraft
during the relative tail WOD conditions, high main rotor washing, the
consequences of high rotor disc loading, are unsatisfactory for single-point ship
operations. Not only does it increase the pilot's workload on the deck, but it also
results in a dangerous environment for flight deck personnel. This hazard could
result in injury or loss of personnel (to the sea), or damage to deck equipment (as
occurred during this investigation).
4. SLIDE AND RECOVERY WIND ENVELOPE DEVELOPMENT
PROCESS
The U.S. Navy's conventional method of investigating the effects of relative
winds above deck on new helicopters during launch and recovery operations, and
then developing the appropriate launch and recovery wind envelopes, is in dire
need of improvement. The current dynamic interface and wind envelope
development process often fails miserably in maximizing the operational
flexibility of ship helicopters, only really achieved by limiting the wind envelope
solely by the limitations of the aircraft's handling quality.
A significant improvement in the dynamic interface process on the ship will
greatly benefit the MH-60S and the fleet ships it will deploy. In addition, a
significantly improved, efficient, scientific process for developing a launch and
recovery wind envelope for the new helicopter will also be of great benefit to the
introduction of the next U.S. Navy helicopter, the SH-60R, which is expected

78
around 2008. Only when new and improved technological approaches to the
investigation of wind effects on the deck of helicopters can be developed, will the
maximum of the ship's actual operational flexibility be achieved. And only then
will the entire U.S. Navy benefit fully from these two helicopters and their
important role in the successful implementation of the Helicopter Master Plan.
79
V. RECOMMENDATIONS
1. LAUNCH AND RECOVERY OF WIND ENVELOPE DEVELOPMENT
i. USS BATAAN (LHD 5)
There are some specific recommendations that should be considered by
The U.S. Navy during future MH-60S testing and before the fleet was introduced
MH-60S helicopters aboard the USS BATAAN (LHD 5).
The day launch and recovery wind envelopes for points 4, 5, 6, and 7,
developed during this investigation and presented in Figures A-16 through A-19,
will allow for safe and operationally flexible ship launch and recovery operations
for the average MH-60S fleet pilot. They must be authorized by
The U.S. Navy, prior to the introduction of the MH-60S fleet, was to be used on
all LHD 1-class ships. Also prior to the introduction of the MH-60S fleet, these
envelopes should be included in the following reference publications: NAVAIR
00-80T-106, Naval Amphibious Assault Ship (LHD/LHA) Standardization
Manual of Training and Air Operations Procedures, and NWP 3-04.1M,
Helicopter Operating Procedures for Air-Capable Ships.
Launch and recovery operations are currently permitted for all sites not
evaluated during this investigation only if the General Launch and Recovery
Wind Envelope for LHD-class vessels (Figure A-8) is used. Launch and recovery
operations of MH-60S to untested points (points 1 to 9 at night; points 1, 2, 3, 8,
and 9 during the day) must use this common cover at the time of fleet
identification until appropriate above-deck wind investigations can be conducted
80
which guarantees the expansion of this approved general envelope. In addition, in
order to maximize the operational flexibility of the MH-60S helicopter aboard the
LHD 1 class ships, further wind investigations should be carried out to untested
points as soon as possible. In addition, since greater launch and recovery wind
envelopes can be achieved for points 4, 5, 6, and 7, additional above-deck wind
investigations should be conducted to these already tested points, if time permits.
To ensure that all aircrew are aware of the hazardous conditions recorded
during launch and tail wind recovery operations aboard LHD 1-class ships,
warning8 should be included in the following reference publications: A1- H60SA-
NFM-000, Naval Training and Operations Standardization Flight Manual, MH-
60S Naval Model Aircraft, and NAVAIR 00- 80T-106, Amphibious Assault Ship
(LHD/LHA) Naval Air Operations Training and Procedures Standardization
Manual. The warning should read: "During the transition to forward flight from
points 4, 5, 6, and 7, aboard an LHD 1-class vessel, with ambient winds above
deck from 090 to 270 relative (i.e. with tail winds), the power required may be
20 to 25% higher than is required in hovering 10 feet above the place."
Currently, the landing point markings painted on each landing point on LHD
1-class ships include wheel markings to be used as a visual reference to assist the
crew when positioning the wheels on deck during landing. As an MH-60S
helicopter
8A NATOPS warning is defined as "an operating procedure, practice or condition, etc., which may
result in injury or death, if not carefully observed or followed" (MH-60S NATOPS, 2002).

81
have not been deployed on these ships, the properly located landing gear markings
are not included as part of the LHD 1 landing site (such as the wheel markings for
the helicopters currently deployed on these ships, i.e. H-46 and H-53). Prior to the
introduction of the MH-60S fleet, wheel markings depicting the location of the
MH-60S wheels required once on deck had to be included as part of each landing
site.
ii. USNS CONCORD (T-AFS 5)
There are some specific recommendations that should be considered by
The U.S. Navy during future MH-60S tests and before the fleet the introduction of
MH-60S helicopters aboard the USNS CONCORD (T-AFS 5).
The day and night launches and wind envelope wind recovery for port and
right approaches, developed during this investigation and presented in Figures A-
20 and A-21, will allow for safe and operationally flexible ship launch and
recovery operations for the average MH-60S fleet pilot. They had to be authorized
by the U.S. Navy, prior to the introduction of the MH-60S fleet, to be used on all
T-AFS 1-class ships. Also prior to the introduction of the MH-60S fleet, this
envelope should be included in the following reference publications: NWP 3-
04.1M, Operating Procedures for Helicopters for Air-Capable Ships.
In order to maximize the operational flexibility of MH-60S helicopters aboard
T-AFS 1 class ships, as greater day and night launches and wind envelope
recovery can be achieved, additional launches and development of recovery wind
envelopes should be carried out for port and right approaches, if time permits.

82
Finally, to ensure that all crew members are aware of the hazardous conditions
recorded during launch and tail wind recovery operations aboard T-AFS 1 class
ships, warnings should be included in the following reference publications: A1-
H60SA-NFM-000, Naval Air Operations Training and Procedures
Standardization Flight Manual, Naval Model MH-60S Aircraft, and in NWP 3-
04.1M, Helicopter Operating Procedures for Air-Capable Ships. The warning
should read: "When performing the launch and recovery evolution of a T-AFS 1-
class vessel, with ambient winds above deck from 090 to 270 relative (i.e. with
tail winds), the power required may be 15 to 20% higher than that required in
hovering 10 feet above the ground."
iii. USNS SIRIUS (T-AFS 8)
There are some specific recommendations that should be considered by
The U.S. Navy during future MH-60S testing and prior to the introduction of the
MH-60S helicopter fleet aboard the USNS SIRIUS (T-AFS 8).
The day launch and wind envelope wind recovery for port and right
approaches, developed during this investigation and presented in Figures A-22
and A-23, will allow for safe and operationally flexible ship launch and recovery
operations for the average MH-60S fleet pilot. They had to be authorized by the
U.S. Navy, prior to the introduction of the MH-60S fleet, to be used on all T-AFS
8-class ships. Also prior to the introduction of the MH-60S fleet, this envelope
should be included in the following reference publications: NWP 3-04.1M,
Operating Procedures for Helicopters for Air-Capable Ships.

83
To maximize the operational flexibility of MH-60S helicopters aboard T-AFS
8 class ships, additional launches and development of recovery wind envelopes
should be carried out for port and right approaches, if time permits.
Since night ship testing is not performed, night launch and recovery operations
are currently permitted for port and starboard approaches only if the General
Launch and Recovery Wind Envelope for T-AFS class vessels (Figure A-9) is
used. The night launch and recovery operations of MH-60S should use this
common shroud at the time of fleet introduction until appropriate above-deck
wind investigations can be carried out which warrants the expansion of this
approved public shroud.
Finally, to ensure that all crew members are aware of the hazardous conditions
recorded during launch and tail wind recovery operations aboard T-AFS 8-class
ships, warnings should be included in the following reference publications: A1-
H60SA-NFM-000, Naval Air Operations Training and Procedures
Standardization Flight Manual, Navy Model MH-60S Aircraft, and in NWP 3-
04.1M, Helicopter Operating Procedures for Air-Capable Ships. The warning
should read: "When performing the launch and recovery evolution of the T-AFS 8
class ships, with ambient winds above deck from 090 to 270 relative (i.e. with
rear winds), the power required may be 15 to 20% higher than that required in
hovering 10 feet above the place."
84
2. PILOT-VEHICLE INTERFACE
i. Common
There are several specific pilot-vehicle interface (PVI) recommendations that
the U.S. Navy should consider during future MH-60S testing, before the fleet
introduces MH-60S helicopters to the fleet, and before the development of next-
generation ship helicopters. These recommendations relate to the front field of
view, cockpit vibration, tail wheel location and main rotor washing.
The recent selection of the MH-60S as the chosen U.S. Navy helicopter
fuselage was primarily based on the urgent need to replace the failed H-46
fuselage as quickly as possible and on the simultaneous availability of the U.S.
Army's previously ordered but no longer necessary Black Hawk fuselage. Thus, in
its acceptance of the U.S. Army's basic H-60 in place of the H-46 airframe, the
U.S. Navy ensured that it received a helicopter not designed for ship missions,
rather than a helicopter designed specifically for it. Thus, the US Navy inherited a
safer fuselage with respect to the age of the fuselage and reliability of
components, but also inherited a fuselage with deficiencies that had been
previously identified and not corrected, and which were not originally designed
for ship operations in general, or, in particular, for the internal and external cargo
operations of ships.
During this investigation, four shortcomings of the pilot-vehicle interface were
identified and all related to inherent problems in hiring aircraft on missions that
were never designed to be performed. In many ways, the helicopter performs
quite satisfactorily, but in some it doesn't. The results of the PVI are lacking

85
mainly due to the inadequacy of the acquisition process mentioned above and the
lack of consideration for the mission or known shortcomings in the design
process. Failure to correct the following PVI shortcomings will not preclude the
successful operation of MH-60S in the fleet. However, the incorporation of the
necessary corrections will certainly improve the efficiency, operational
effectiveness and safety of the operations and missions in which the helicopter is
used. At the very least, these PVI deficiencies should be identified as extremely
dangerous to the relevant personnel (aircrew and deck crew) in the appropriate
reference manuals and during the training of the ship's helicopters.
ii. Front View Field
The very limited field of view (FOV) observed during all phases of ship
operation and wind envelope testing should be corrected as soon as possible. An
engineering investigation should be carried out to determine whether or not a very
large size of glare shield jutting into the instrument panel is fully necessary, and
whether or not a smaller one is feasible. A well-designed smaller glare shield can
provide a better forward FOV, especially during slowed flights, while still
providing adequate glare protection for the instrument panel.
These shortcomings can easily be avoided during the initial cockpit
development and helicopter design, when consideration must be given to the
requirements of the airframe and its mission, for the typical or generic helicopter
shortages that must be addressed or minimized, and for the outstanding legacy
shortcomings. In the case of the MH-60S (and SH-60R) many considerations
must be present

86
was given for the incorporation of corrections for the well-documented
shortcomings of FOV identified in all older H-60 models (which only got worse
with the MH-60S and its larger instrument panel). FOV has been identified as
unsatisfactory and unsafe in all H-60 models for nearly two decades, yet continues
to be ignored by the acquisition process, despite the fact that FOV is directly
responsible for a number of aircraft accidents and crashes.
Finally, to ensure that all aircrew are aware of the dangers inherent in the very
limited forward FOV while operating aboard the MH-60S helicopter, warnings
should be included in the following reference publications: A1-H60SA-NFM-000,
Naval Air Operations Training and Procedures Standardization Flight Manual,
Naval Model MH-60S Aircraft, and in NWP 3-04.1M, Helicopter operating
procedures for air-capable ships. The warning should read: "The pilot's and
copilot's field of view is severely limited during approach to the ship's deck,
primarily due to the cockpit obstruction and high nose attitude required for
deceleration, and may result in a collision with the ship, deck personnel, deck
equipment, or gradual loading."
iii. Cockpit Vibration
The excessive and almost constant vibration of the main rotor observed in the
cockpit when operating in a low airspeed regime during ship operation and wind
envelope testing should be corrected as soon as possible. Instrumental
investigations should be carried out to determine the specific nature and origin of
these excessive vibrations. Since such vibrations have not been documented in
similar fuselages (US Navy H-60B/F, US Army H-60A/L), investigations

87
it may be necessary to focus on the unique configuration and components of the
MH-60S: prototypical cabin vibration dampers, prototypical tail masts, common
cockpit avionics locations in transition sections (and the resulting rear center of
gravity), high operational gross weight of the aircraft, etc.
These shortcomings could easily have been avoided, perhaps, during the
development of the initial helicopter design, when consideration had to be given
to the requirements of the airframe and its mission, and the prototypical
incorporation of the airframe and cockpit components. In addition, these
vibrations were identified many years ago during an initial MH-60S proof-of-
concept demonstration by contractors but were largely ignored until the start of
government development testing. In addition, although identified by the
government as significant and potentially dangerous, the correction of these
shortcomings has not been incorporated and will not preclude the introduction of
the fleet and the use of MH-60S helicopters.
Finally, to ensure that all aircrew are aware of the dangers inherent in the
excessive and continuous vibration of the main rotor observed in the cockpit
while operating in a low airspeed regime during operations on board the MH-60S
helicopter, the warning should be included in the following reference
publications: A1-H60SA-NFM-000, Naval Air Operations Training and
Procedures Standardization Flight Manual, The MH-60S aircraft of the Navy
model, and in NWP 3-04.1M, the operating procedure of the helicopter for air-
capable ships. The warning should read: "Cockpit vibrations during low-airspeed
flights are exhausting and distracting, may result in reduced situational awareness
and carelessness

88
during a landing at the end of a long mission or during an extended VERTREP
operation, and may ultimately cause a helicopter or load impact with the ship's
deck or with the ship's deck personnel."
iv. Tail Wheel Location
The tail wheel location is too far behind and should be repaired as soon as
possible. An engineering investigation should be conducted to determine the
feasibility of moving the tail wheel significantly forward from its current location.
When the U.S. Army's UH-60A Black Hawk fuselage was modified for use by the
U.S. Navy (as the SH-60B) in the early 1980s, one of the modifications made was
the location of the tail gear. The SH-60B's tail wheels are well ahead of the
original Black Hawk's tail wheel position to minimize the ship's deck footprint
and pilot workload associated with aircraft landings with a larger footprint on the
ship's deck at one point. In the acquisition of the MH-60S fuselage (essentially the
UH-60A fuselage), the U.S. Navy had received the original U.S. Army Black
Hawk tail wheel location, a location that was initially deemed unacceptable for
ship operations.
Relocating the current MH-60S tailwheel location to the SH-60B and SH-60F
tailwheel locations will significantly reduce the likelihood of the tail wheel impact
height with the ship's structure, deck personnel, or deck equipment during
onboard landing or cargo retrieval, and provide another 3 to 5 feet of clearance
between the tailgate and the deck environment during a nose-up stance. In
addition, although the location of the tail wheel was not identified as a
shortcoming with respect to the dimensions of the deck available for landing
when compared

89
to the aircraft's footprint, the relocation of the tail wheels would significantly
reduce the longitudinal dimensions of the MH-60S (from about 29 feet to about
18 feet). This will undoubtedly improve the already satisfactory conditions when
landing on T-AFS-class ships, but also when landing on ships of other classes
with smaller single-point decks (e.g. cruisers and guided missile destroyers).
Finally, to ensure that all crew members are aware of the hazards inherent in
the rear location of the tail wheel during operations aboard the MH-60S
helicopter, warnings should be included in the following reference publications:
A1-H60SA-NFM-000, Naval Air Operations Training and Procedures
Standardization Flight Manual, Naval Model MH-60S Aircraft, and in NWP 3-
04.1M, Helicopter operating procedures for air-capable ships. The warning
should read: "The height of the tail wheel above the deck must be carefully
managed, especially during load pickup. Due to the location of the tail wheel
behind the fuselage, and the requirement for a nose-up stance during deceleration,
there is a potential for tail wheel contact with deck edges, flight decks, hook
personnel, or external loads during approach to the ship's deck.
v. Down Wash Main Rotor
The under-washing of the main rotor of the MH-60S helicopter is particularly
strong, especially at the high gross weight of the aircraft and during operations on
board with relative tail winds. This results in increased cockpit vibration and pilot
workload during ship operation, and is dangerous to deck personnel.

90
An engineering investigation can be carried out in the interest of rectifying this
situation, however, it is already known as a consequence of the high loading of
the rotor discs, and the operation of large helicopters around the deck of the ship.
Increasing the size of the main rotor to reduce the size of the disc loading
operationally is not possible due to the limited size of the environment available
during the operation of the vessel. And preventing cargo aircraft from operating at
the highest operational gross weight significantly limits their operational
capabilities. To ensure the availability of effective medium lift helicopters for ship
operations, all that can really be done with respect to the washing of powerful
helicopters is the identification of this phenomenon to those involved in the
operation of ship helicopters. In addition, and only if operationally feasible, tail
wind operations can be minimized, as can operations with cargo with high gross
weight and large fuel loads.
Finally, to ensure that all personnel involved in the direct support of flight deck
operations of the MH-60S are aware of the powerful main rotor washout during
operations on board the MH-60S helicopters, warnings should be included in the
following reference publications: A1-H60SA-NFM-000, Naval Air Operations
Training and Procedures Standardization Flight Manual, MH-60S Naval Model
Aircraft, and in NWP 3-04.1M, Helicopter Operating Procedures for Air-
Enabled Vessels. The warning should read: "Washing of the main rotor during the
operation of the vessel, especially at high gross weight of the aircraft or in
conditions of relative tailwinds, can be very significant, and may result in injury
to deck personnel or equipment damage."
91
3. SLIDE AND RECOVERY WIND ENVELOPE DEVELOPMENT
PROCESS
Since the current process is inadequate and not conducive to the development
of an "ideal" launch and recovery wind shield, limited only by the lack of aircraft
handling quality, more must be done to take advantage of the extraordinary
technological advances made in this and related field of study, and to use the data
that has been collected by the institutions that carried out similar tests.
In particular, the U.S. Navy should conduct a detailed comparative study of
the H-60, use mathematical and aerodynamic prediction tools, and mandate better
ship helicopter design.
First and foremost, the U.S. Navy must determine what H-60 ship
investigations have been conducted, or are being conducted. Data from previous
and ongoing wind investigations on the deck of the H-60 ship must then be
identified and collected. A comparative study will produce whether the data can
be applied or used by MH-60S ship test efforts. Ideally, a comparative study could
identify significant trends in handling quality and potentially hazardous above-
deck wind conditions, perhaps allowing prediction of wind envelopes without
actual testing, or perhaps even allowing the use of one H-60 model envelope by
another H-60 model. In any case, without question, knowledge of the efforts and
results of past and ongoing H-60 ship trials, will be of great benefit to the future
MH-60S and, ultimately the SH-60R, the launch of the ship and the development
of the recovery wind cover. Amazingly, none of the H-
60 ship test data studied before the start of MH-60S

92
ship testing. It is recommended that the MH-60S test attempt does not continue
without doing so, and that the great experience of the H-60 that has been gained
on board is logically studied and used in future MH-60S (and all H-60) ship test
attempts.
The second action that the U.S. Navy should take in the full integration of all
available assets to modernize its process investigating the effects of relative winds
above deck on helicopters is to fully embrace rapidly evolving mathematical and
aerodynamic prediction technologies. The use of such prediction technology is
critical in efforts to improve the launch and recovery of wind envelope
development. The cost implications, efficiency, and safety are outstanding. Again,
while it may seem remarkable, none of the aforementioned prediction or
simulation technologies were used prior to the start of testing of the MH-60S ship
(even more remarkable when one considers that some of the most successful
prediction efforts underway were at least partially initiated by the U.S. Navy). It is
recommended that the MH-60S testing effort does not continue without the
utilization of this remarkable prediction tool to aid in the definition and
visualization of air rise and turbulence, and the prediction of possible wind
envelopes, possible deficiencies in aircraft handling quality, and hazardous
conditions.
The third important step the U.S. Navy should take in improving the dynamic
interface test process and in maximizing the results of future on-deck wind
investigations is to continue its involvement in research into aircraft design
standards. This effort is complicated and expensive that combines many

93
advanced technologies (e.g. variable stability aircraft and simulation of complex
helicopters on ships) and require a lot of cooperation among various interested
institutions. Of course, this is the only recommendation, of the three made
(comparative studies and the prediction tool being the other two) the most
significant will affect the development of the ideal launch and recovery wind
envelope. However, it is also one of the furthest from complete development
(with respect to the completion of actual ship design standards) and
implementation (especially at the contractor level during future helicopter
design/concept considerations). In addition, this effort is severely underfunded,
and the development of a naval helicopter based on an unspecified design
standard is hard to imagine. Of course, the MH-60S is not, but future naval
helicopters certainly have to be developed and evaluated according to detailed
ship design criteria.

