


1
MODELING AND ANALYSIS OF POWER AND ENERGY
METRICS IN NAVAL SHIP SYSTEMS
Introduction
Naval ship design is a complex system of activities, integrating the operational needs,
physical constraints, and logical connectivity of various systems into a single unified platform.
For surface combatant ships, missions as diverse as ballistic missile defense to anti-submarine
warfare determine the needs of combat systems, including sensors, processing, communications,
payload, and operational strategies. For this mission system to work, the ship must have a stable,
seaworthy hull, as well as an adequate power and energy (P&E) system.
The U.S. Navy's surface fleet is currently in a period of transition, facing challenges in the
form of recapitalization of aging ships, accelerating technological innovation, uncertainty
regarding future combat systems, and large investments in designing and building new classes
of ships. Most of today's fleet was designed in the post-Cold War era, reflecting geo-political
needs since the 1980s, such as the adoption of the Aegis combat system and the SPY-1D radar.
However, after more than 40 years of operation, these ships are nearing the end of their service
life, and the Navy needs new ships capable of supporting operations for the next 50 years.
In addition, the acceleration of technological change adds uncertainty regarding the future
needs for key combat system elements. The value of a system is determined by its ability to
remain missionally relevant at an affordable cost in an ever-evolving operational context.
Mission system technologies under development are increasing the need for new electrical
power, driving attention to additional properties such as flexibility and scalability beyond
traditional functional requirements. This is important considering the lifespan of the platform
which is designed for 30 to 40 years.

2
Affordability requirements also encourage the study of cost versus capability trades from
the beginning of the design process. System metrics are needed to measure performance,
provide insight into systems-of-systems (SoS) architectures, and support design decisions. With
R&D and Acquisition budget constraints and a new P&E system development schedule, a
comprehensive evaluation of the design space is required to determine the optimal solution.
Metrics based on the "ility" property provide an important tool for designers to differentiate
design options within a broad solution space.
This thesis presents findings from a literature review related to the requirements and
property relationships of "ility" in system systems, as well as methods to distinguish optimal
solutions in the design space. The study developed a hierarchy of "ility" relationships for naval
power and energy systems, resulting in a framework for outlining high-level requirements into
metrics that can help identify dominant architectures in the early stages of design. The
framework considers the physical, logical, and operational aspects of the architecture,
identifying factors that can affect a system's ability to maintain value throughout its lifecycle.
The deepening of flexibility, one of the significant "ility" properties, is explained through
five case studies with proposed metrics for power and energy systems. The study aims to
provide a repeatable process for developing metrics that are integrated into early-stage design
tools, such as the Smart Ship System Design (S3D) design environment being developed by the
Electric Ship Research and Development Consortium (ESRDC).
Naval Power and Energy Systems
The power and energy system is responsible for providing propulsion and the ship
electrical power required to perform the mission requirements of the platform. The current
surface fleet consists primarily of vessels with a P&E system architecture that separates the
propulsion and power generation functions through the implementation of special propulsion

3
turbines connected directly to the propeller shafts and separate ship service generators installed
to provide electrical power on distributed vessels. This type of mechanical-electric configuration
has become a profitable and cost-effective design over the past century, as the demand for
propulsion power has significantly exceeded the demand for combat system power. The DDG-
51 class, for example, has about 78 MW of dedicated propulsion power on the shaft, compared
to 9 MW of separate ship service power.
The Navy's newest class of destroyers, the DDG-1000 Zumwalt class, introduced an
alternative power and energy system architecture, the Integrated Power System (IPS), in which
all power generated on board is shared between the propulsion load demand and the distributed
electrical power demand, including the mission system load. The ship's ability to share 78 MW
of power across all platform functions is made possible by the inclusion of electric propulsion
motors, improved power distribution and power control. Power and energy systems can be
further broken down into seven basic module types, as described in the Navy's Next Generation
Integrated Power System Roadmap (Doerry, 2008):
Power Plant Module (PGM)
Engine Propulsion Module (PMM)
Power Load Module (PLM)
Power Distribution Module (PDM)
Power Conversion Module (PCM)
Energy Storage Module (ESM)
Power Control Module (PCON)
The performance characteristics of power and energy systems can be traced to the physical,

4
logical, and operational characteristics of the sub-module configuration. It is important to
outline the desired functional and non-functional requirements to the lowest level of
measurability, as they can often be met by a variety of architectural configurations. For example,
IPS architecture provides an increase in flexible power capacity over traditional mechanical
architectures based on the total installed power residing within the power generation module,
and is divided between the power generation and propulsion modules as in mechanical
architecture. However, alternative measures of flexibility, such as the ability to serve high-scale,
short-duration pulse load types, may be overall architecture agnostic and more dependent on the
configuration of specific sub-modules, such as energy storage modules. When comparing power
and energy system architecture alternatives, designers need to consider the capabilities of the
fully integrated system and the dependencies between the applicable modules.
1.1 Design Requirements
The U.S. Navy's ship design program is most commonly classified as a Major Defense
Acquisition Program (MDAP) within the Defense Acquisition System and is subject to the Joint
Capability Development and Integration System (JCIDS) process for Acquisitions,
Requirements, and Funding. JCIDS supports the Joint Requirements Supervisory Board's
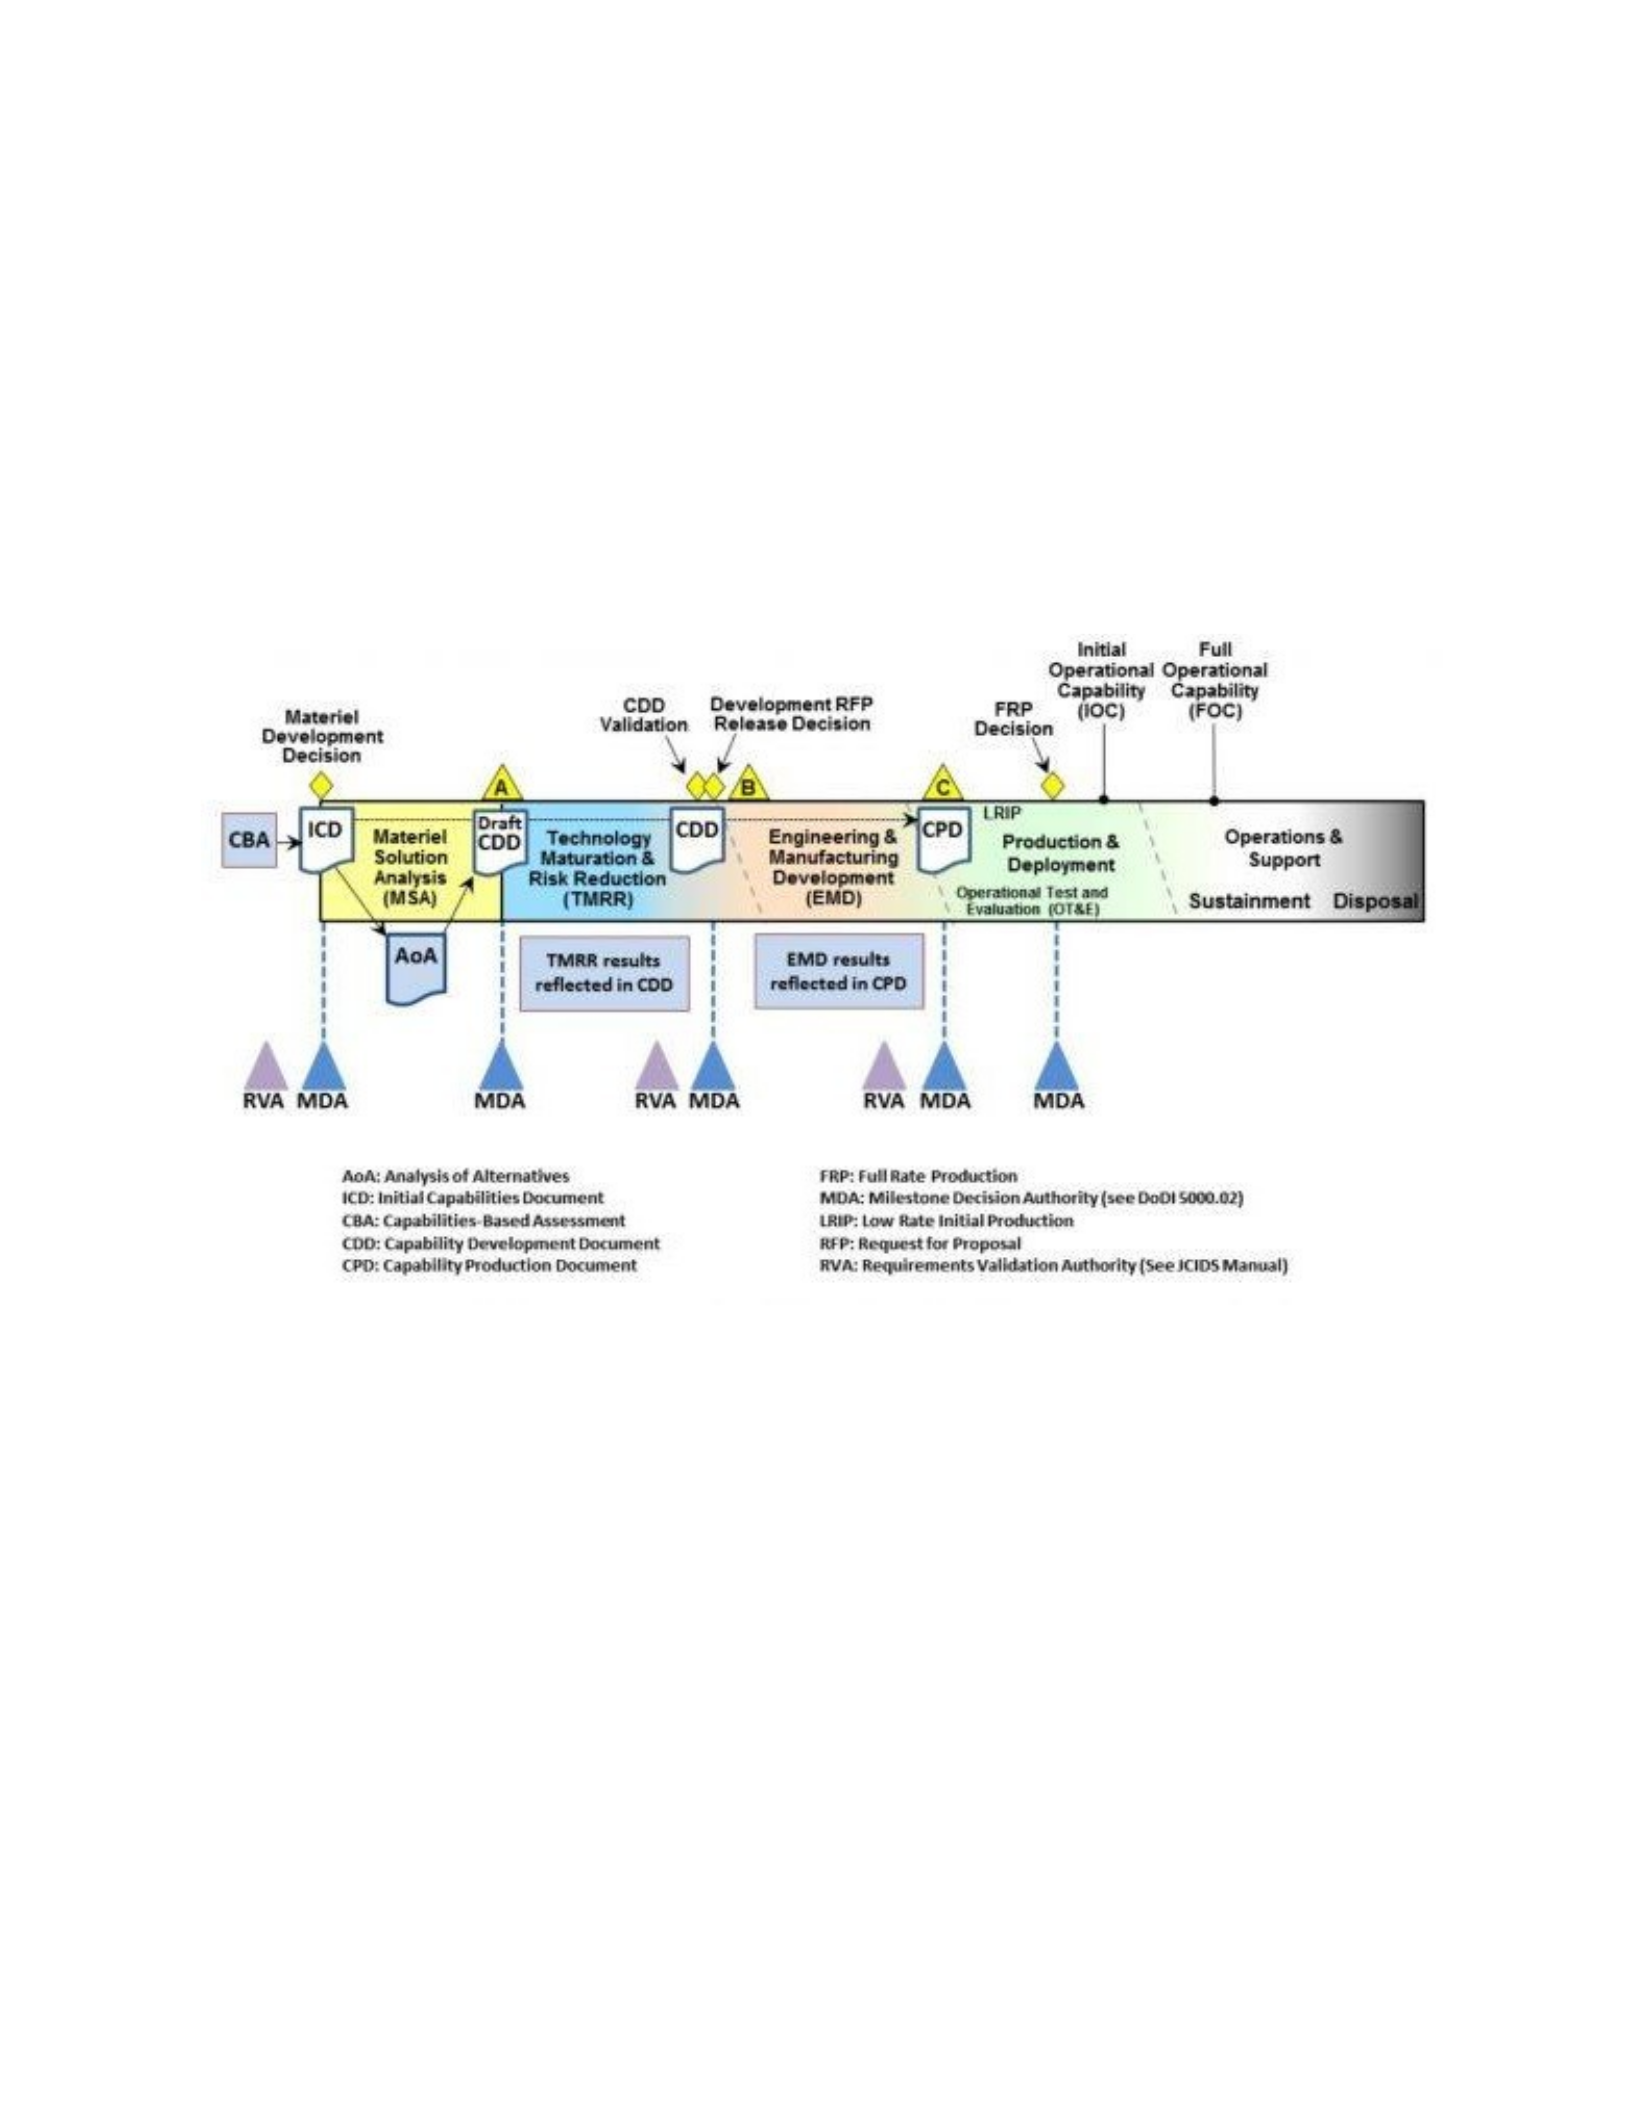
(JROC) responsibility to validate combat capability requirements. Figure 1 illustrates the JCIDS
and Defense Acquisition process as per the 2021 JCIDS Manual, with core elements of
capability requirements development and validation, as described by the Defense Acquisition
University (DAU, 2023). High-level operational requirements, including capability gaps and
mission needs, are identified during the Capability Base Assessment (CBA), and captured in the
Initial Capability Document (ICD) for outcomes recommending material solution approval.
Alternative Analysis (AoA) compares potential material solutions based on mission-level
5
requirements for "operational effectiveness, conformity, and lifecycle cost" (DAU, 2023). The
results of the AoA inform the development of a draft Capability Development Document
(CDD), which consists of threshold values and objective performance for Key Performance
Parameters (KPPs) and Key System Attributes (KSAs). The draft CDD was matured during the
Technology Maturation and Risk Mitigation Phase, which corresponds to the Initial Design
Phase for the design of U.S. Navy ships.
Figure 1: JCIDS and the Defense Acquisition Process (DAU, 2023)
In Navy ship design, CDD requirements are outlined, assigned, and allocated to individual
systems within the ship's SoS, using Systems Engineering principles, to guide the design. In
addition to the CDD capability requirements, the ship's design will be subject to other design
criteria, including the Department of Defense (DoD) and Navy-specific Military Specifications
(MIL-SPEC) and Military Standards (MIL-STD). The Ship Systems Specification Document is
developed in conjunction with system and subsystem design activities to capture the total set of
requirements subject to the platform, applied down to the subsystem level. This specification

6
identifies the design criteria and standards, constraints, and system interfaces required to meet
the platform's performance requirements. The Vessel Specification Document is required to
support the review of the Milestone B program and is a key component of the Technical Data
Package (TDP) which represents the basic design of the vessel to be included in the Design
Detail & Construction (DD&C) Request for Proposal (RFP).
Design decisions are made at the system and subsystem level during the vessel design
process to meet end-to-end performance and cost requirements. Permutation of architectural
options within each subsystem domain creates a space for potential solutions of high magnitude
that are difficult to evaluate. Beyond the ability to meet predefined requirements and
specifications, additional performance metrics for non-functional requirements are required to
evaluate and rank design options within the trading space.
1.2 Early Stage Design
The early-stage design includes a range of engineering activities undertaken prior to the
Acquisition of Milestone B. It includes the study and analysis of trades conducted during the
Capability-Based Assessment and Alternative Analysis in the requirements development
process, as well as
7
as an initial system architecture effort in the period of Material Solution Analysis and
Technology Maturation and Risk Mitigation. In the language of ship design, the initial stage
design is carried out in the Concept Formulation (CF) and Initial Design (PD) Phases. Figure 2
illustrates the design phase for the notional Navy ship acquisition program. In this construction,
requirements development activities, including a cost versus capability trade study, are
conducted to define the Top-Level Requirements during the Concept Formulation phase that is
incorporated into the Draft CDD. Initial Design begins after a stable set of system requirements
are established, and the design program can demonstrate the ability to achieve them in a viable
basic ship concept. The early-stage components of PD focus on the selection of the main system
and the identification of sub-systems.
Design
Phase
Concept
Design
Initial Design Contract
Design
Detail Design
Engineerin
g Activities
Set-Based Design Functional
Design
Production
Design
Product •Balanced
Requirement
Set
•Program plan,
budget,
process
•Set
identification,
•Global
ship
configurat
ion,
dimensio
n key
•Define
d
•Basic
function
al
specifica
tions
•Acceptab
le SoS
Fees
•Basic
allocated
specificatio
ns
•Bidding
package
for the
awarding
•Productio
n work
package
•Final
cost
assess
ment
•Required
8
System
System (SoS)
•Initial
Specifications
•Eligibility
assessment
•System
engineering
process
•System
development
plan
subsist
ence
•Specific
ations
tailored
to the
subsyste
m
•Identify
critical
risks and
approved
mitigation
plans
•Verification
requirement
s met
•Risk
mitigatio
n
activities
complete
d
•Systems,
equipme
nt.
Develop
ment of
procure
ment
specifica
tions
of
constructi
on
contracts
•3D Product
Models
•System
paths and
routing,
deconflict
•Vendor
selection
and
contracts
•Product
ivity
assessm
ent
specification
mods.
Approved
departure
from
specification
•Production
schedule
•System
activation
package
•System
Engineering
Validation
Figure 2: U.S. Navy Ship Acquisition Phases, Activities, and Products Notional
The description of the notional program in Figure 2 illustrates the use of the Set Based
Design (SBD) approach for Concept Formulation and Initial Design. (JE Page, 2022) describes
the implementation and organization of the Set-Based Design process currently being carried out
by the U.S. Navy's next-generation large surface warfare program, DDG(X). SBD relies on the

9
principles of concurrent engineering, decision deferral, and increased exploration of the design
space to make design decisions through the elimination process. This is achieved through the
decomposition of the SoS with the design of the domain or competence and the establishment of
a set of alternative solutions. (JE Page, 2022) explains the execution of SBD through the
following three adjacent design activities:
1. Articulate a series of every conceivable solution to the problem that has been
presented.
2. Remove from this pool a subset of all unviable solutions.
3. Remove from the remaining set all existing solutions the better
(dominating) solution.
The design of modern Navy ships relies on a mixture of computer-aided tools capable of
initially characterizing the concept of a synthesized ship and the definition of a particular
system with high precision Architecture. For the Navy's power and energy systems, the ESRDC
Intelligent Ship System Design is a tool developed by the U.S. Navy to define, analyze, and
understand the performance of power and energy flows in distributed systems. This allows
designers to quickly characterize the physical implications of the notional power and energy
system architecture in terms of weight, volume, and location of associated components during
early-stage design activities. The logical and physical connectivity between system components
is defined across a variety of disciplines, including electrical, mechanical, and plumbing
subsystems. Today, S3D is used to analyze energy flows across all subsystems and components
to verify power supply, demand, and distribution requirements are being met within a larger
system. The ability to incorporate additional performance metrics and non-functional
requirements in such a device will provide greater insight to system designers in making design

10
decisions within a trading space set out based on feasibility and dominance.
2Literature Review
Literature reviews are conducted to survey existing knowledge bodies related to
"ilities" in complex system design. The design community is found to use the term "ility" with a
variety of similar definitions, as summarized in Section 2.1. This research was conducted at the
beginning of the thesis process to provide context on the state of the published work related to
the utilization of ilities and design metrics in various SoS engineering processes and to identify
priority design focus areas within the specific discipline of naval power and energy (P&E)
systems. Two initial hypotheses were formulated for the structuring of the research, with their
intended application in the framework of a new early-stage P&E design. The first is that a
relationship exists between individual diseases in such a way that the optimization of one
person may have a positive or negative impact that coincides with another. The second is that,
in complex system-of-system designs, the lowest level of the system definition is the selection
of design variables that are combined to form the metrics used to measure illiteracy.
The following review documents the state of practice and implementation as published
through various professional and academic forums. Several consistent themes were found related
to the interconnectivity of individual diseases and the general way in which they were prioritized
to improve the value function of the system. Various methods for analyzing performance and
cost value when comparing alternative architecture decisions are captured below in three
categories: Caus-Effect Mapping, Differential Analysis, and Scenario-Based Evaluation. A
separate line of research is also discussed, which outlines systems based on spatial, functional,
and
temporal characteristics. Finally, an additional focus is placed on the "flexibility" of emerging and

11
how it relates to the characteristics of the system that are prioritized more frequently.
2.1 Disease
Starting with a broad exploration of ilities for complex system systems, some common
themes and definitions are found throughout the published material reviewed. The primary
objective of defining a disease centers on the maintenance of system values over time. These
needs arise from the identified differences between the functional requirements used to define
The goals and weaknesses of the current system are used to measure the system's ability to
respond to change. Temporal aspects of change are prevalent throughout the literature,
including lifecycle performance and value discussions. However, there seems to be conflicting
terminology used to articulate this goal. One common conflict is the overlap between the
definitions of ilities and metrics.
(Ricci, Fitzgerald, Ross, & Rhodes, 2014) defines system-of-system ility with a lifecycle
value property that allows the system to "maintain value delivery over time by responding to
exogenous changes in the operational environment." They suggest the temporal aspect of ility,
where the given value is not realized until after the system is operational. This aspect differs
from the traditional functional requirements, which are established to determine the initial
primary value of the system. The authors outline the System of System Architecting with Ilities
(SAI) method, discussed in Section 2.3.2, which provides examples of a set of evaluation
metrics to compare design alternatives that include "operability" in addition to quantitative
criteria such as cost and multiple uses. They went on to explain the need to evaluate SoS
architecture alternatives against a variety of metrics, including "value metrics", such as attributes
and costs, and "ility metrics", which are determined by evaluating the impact of shifts in the
context of a system or requirement from one moment to another.

12
(Chin, Yau, Kok Wah, & Khiang, 2013) describes ilities as "attributes that characterize a
system's ability to respond to change, both predictable and unpredictable." They are
presented as a non-functional requirement necessary to ensure the delivery of value throughout
the life cycle of the system system. The authors make a point to acknowledge the cost of
implementing ilities and the potential conflicts between certain ilities that will require decision-
making tradeoffs in architecture. These considerations emphasize the need for a balanced design
approach that takes into account the broader context and requirements of the system.
(Doerry & Amy, 2019) discusses the key requirements for surface combat power and
propulsion system design. The authors present a mixed discussion of the three prioritized
metrics (size, weight, cost) and disease (flexibility and survivability) that greatly influence the
metrics.
They identified the drivers of requirements implementation as a mixture of metrics and ilities:
the projected future mission system load, which is a metric, and the system survival criteria,
including CONOPS, which are ility.
(Guariniello & DeLaurentis, 2014) calls for the important role that metrics play in the
definition of ilities as the impact of functional and developmental dependencies "on metrics that
characterize the global nature of a system over its lifetime." They suggest that metrics represent
capabilities at the individual system level but do not directly translate to system-level systems.
Higher level metrics at the SoS level are called ilities.
2.1.1 Hierarki Ility
Various hierarchies and decompositions of ility are found throughout the literature to better
define ility as a measurable attribute of the system. Certain diseases, such as

13
Survivability, identified as having strong roots in the requirements of traditional systems, while
others, such as evolutionary ability, are less easily defined. This decomposition suggests that
there is a clear relationship between the individual's ility and the different ways to approach the
attributes of the desired system. Many of the diseases discussed extensively in literature reviews
are desirable attributes of the naval P&E system.
Research by (deWeck, Ross, & Rhodes, 2012) to unravel the relationship between the life
cycle properties of systems resulted in a proposal of "hierarchical means-end relationships
among ilities." The authors first acknowledge that certain diseases, such as safety and reliability,
have been historically prevalent in system design systems, although they are considered
secondary requirements to requirements that can be quantitatively tested by traditional processes.
Through the authors' own experience and subject matter expertise, they developed a list of
twenty principles.
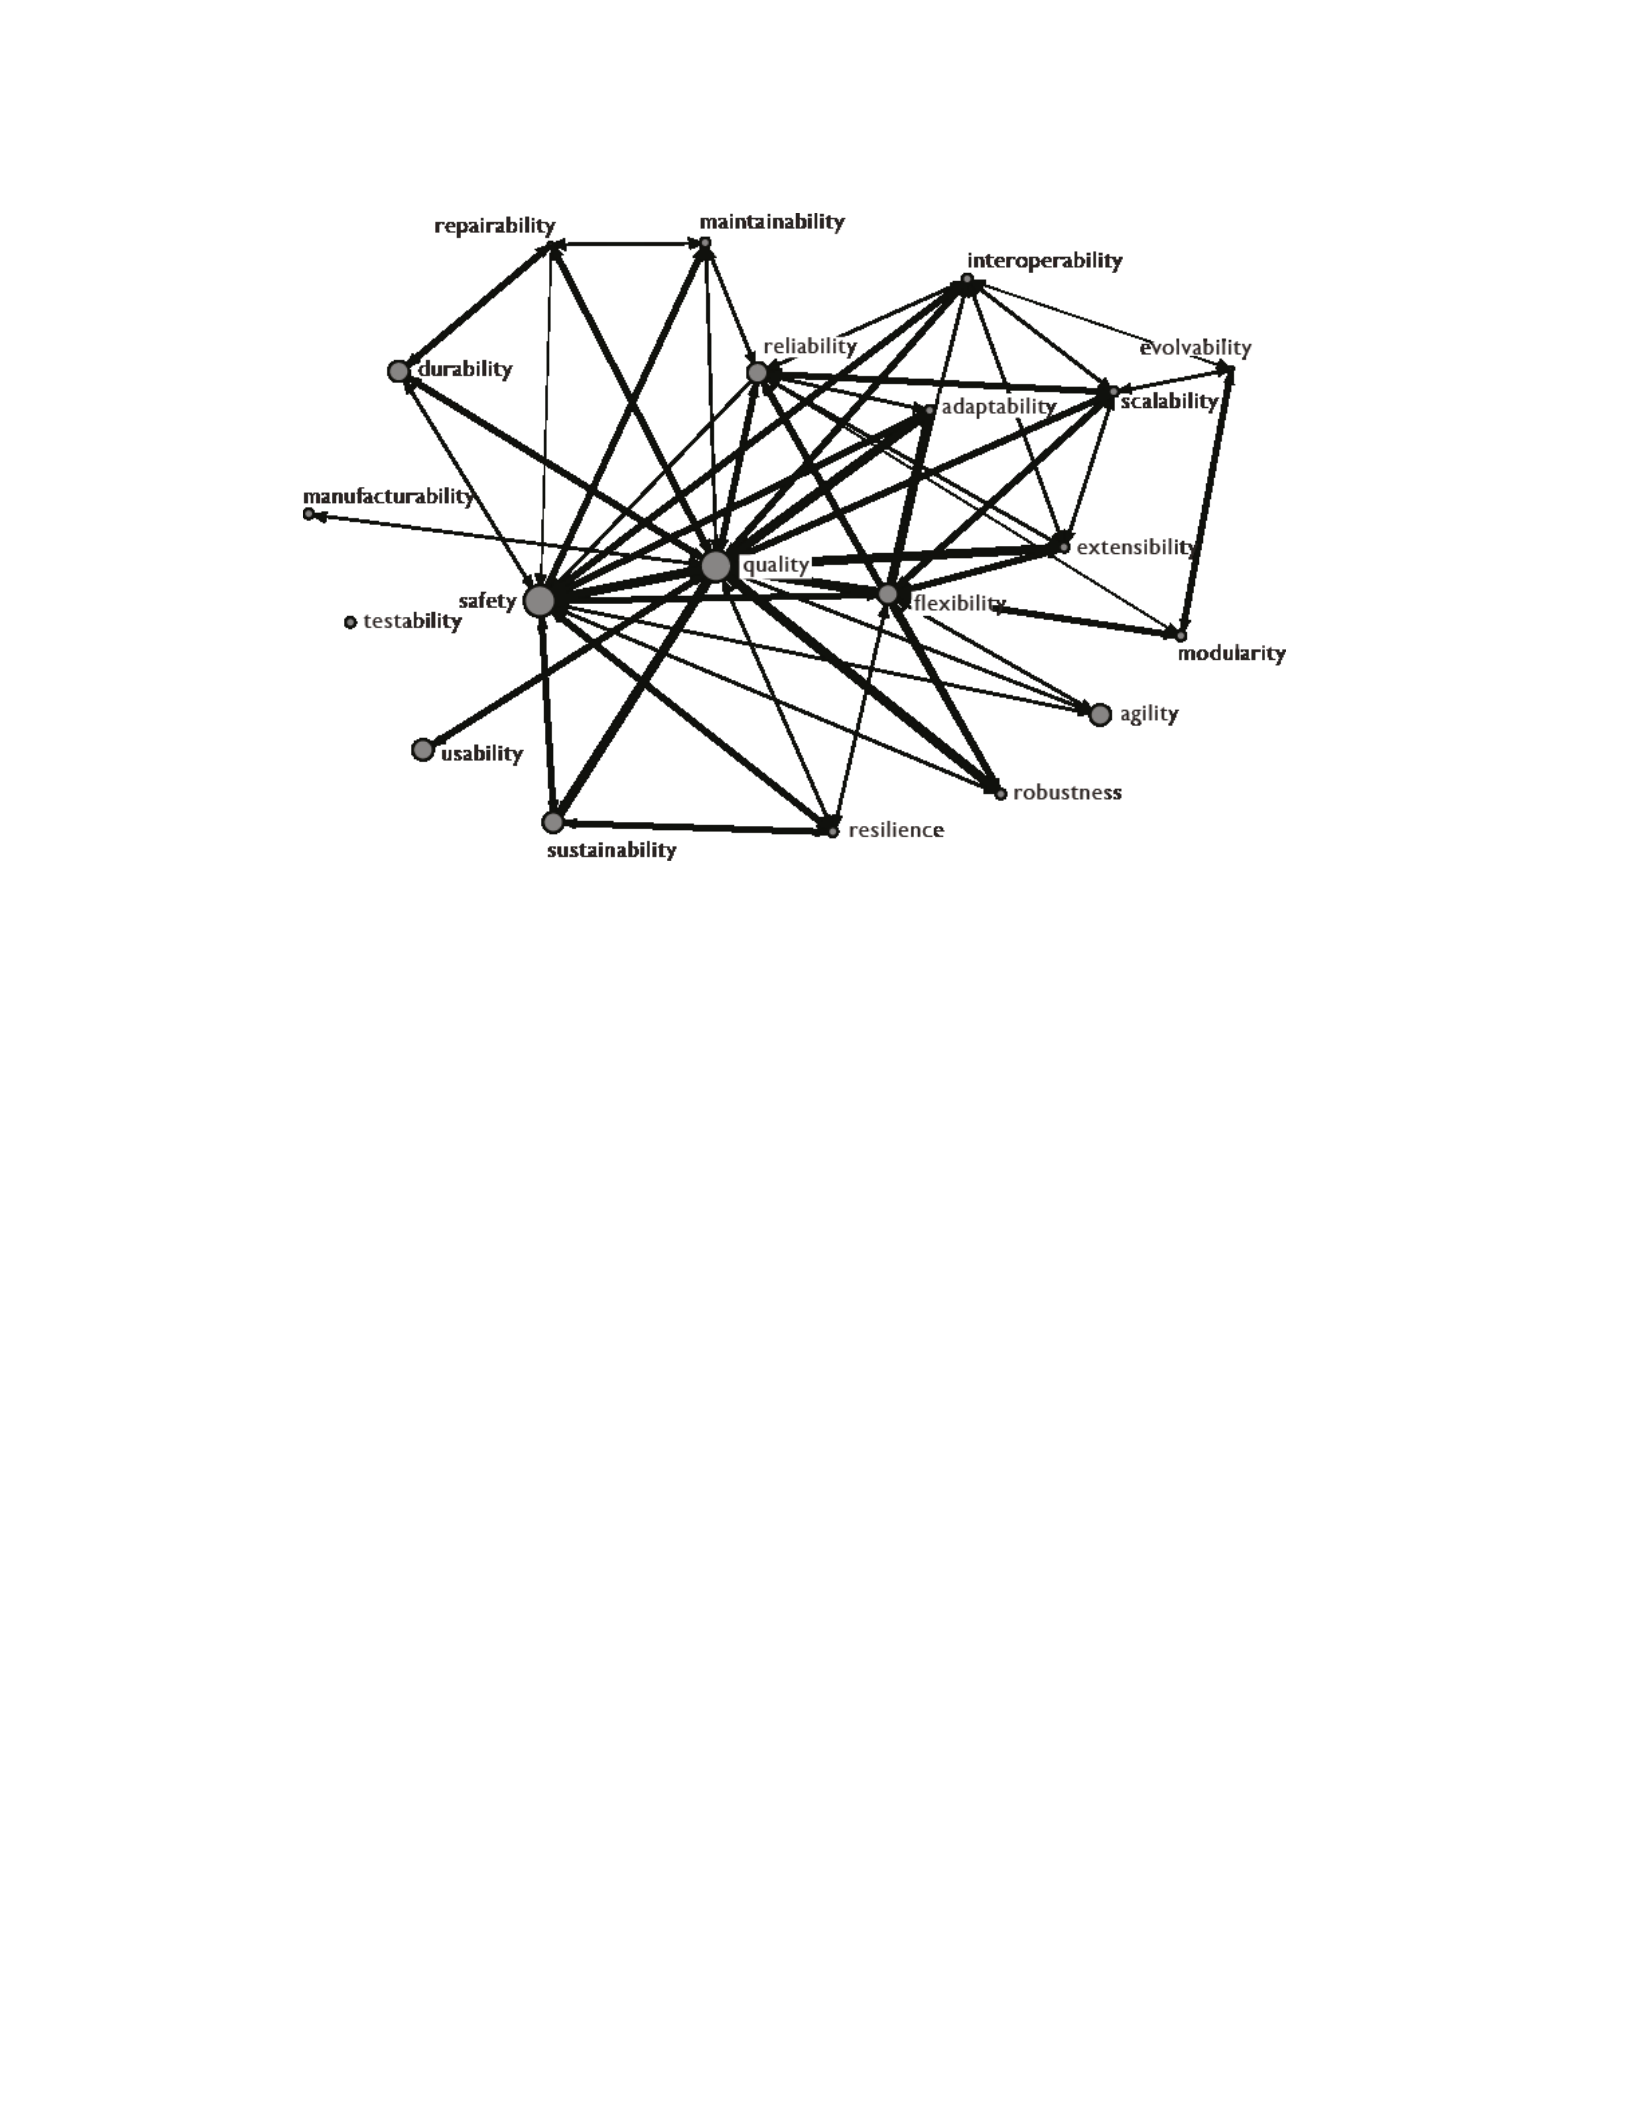
They conducted a research survey to collect data on the frequency and occurrence of concurrent
citations, to develop a model of the potential relationship between ilities, shown below in
Figure 3.
14
Figure 3: The emergence of inequalities in literature reviews with implicit dependence (deWeck,
Ross, & Rhodes, 2012)
Based on the prevalence and concurrent occurrence of a particular ility, the authors
propose a hierarchical structure of ility means, in which one ility can serve as a means to
achieve another or goal. The authors recommend considering weaknesses in terms of system
nature versus capabilities in one particular area. The authors identified a hierarchy of potential
means by conducting a preliminary exercise with a group of researchers with experience
working with ilities and were given a general set of definitions for twenty ilities. Of interest to
this thesis literature review, further exploration into the initial set of twenty ilities identifies
survivability, change, and robustness as the "ends" at the top of the hierarchy, flexibility in the
middle of hierarchical relationships, and modularity and interoperability as samples of
"means" at the bottom of the hierarchy. Figure 7 in Section 2.1.1 will be further

15
define these interesting halas and show their relationship in the context of the Navy's power and
energy systems.
(Chin, Yau, Kok Wah, & Khiang, 2013) presents a framework for managing system
systems through the identification of ility hierarchies. The authors propose that two specific
diseases, robustness and evolution, are essential for maintaining the ability of SoS to meet
basic operational requirements and future unforeseen requirements later in the system's lifetime.
Because SoS architectural requirements are capability-driven, they are typically evaluated
against predefined missions and scenarios. This condition ensures that the system can meet
performance requirements once "operational contingencies" are introduced to value-driven
scenarios. In their system hierarchy, the authors outline robustness to include survival and
sustainability. Their framework continues to identify flexibility and interoperability as the keys
to making it possible.
(Richards, Ross, Hastings, & Rhodes, 2009), in his discussion of various perspectives for
defining resilience, introduces flexibility and robustness ilities as "the properties of temporal
systems that determine the extent to which a system can maintain or even improve function in
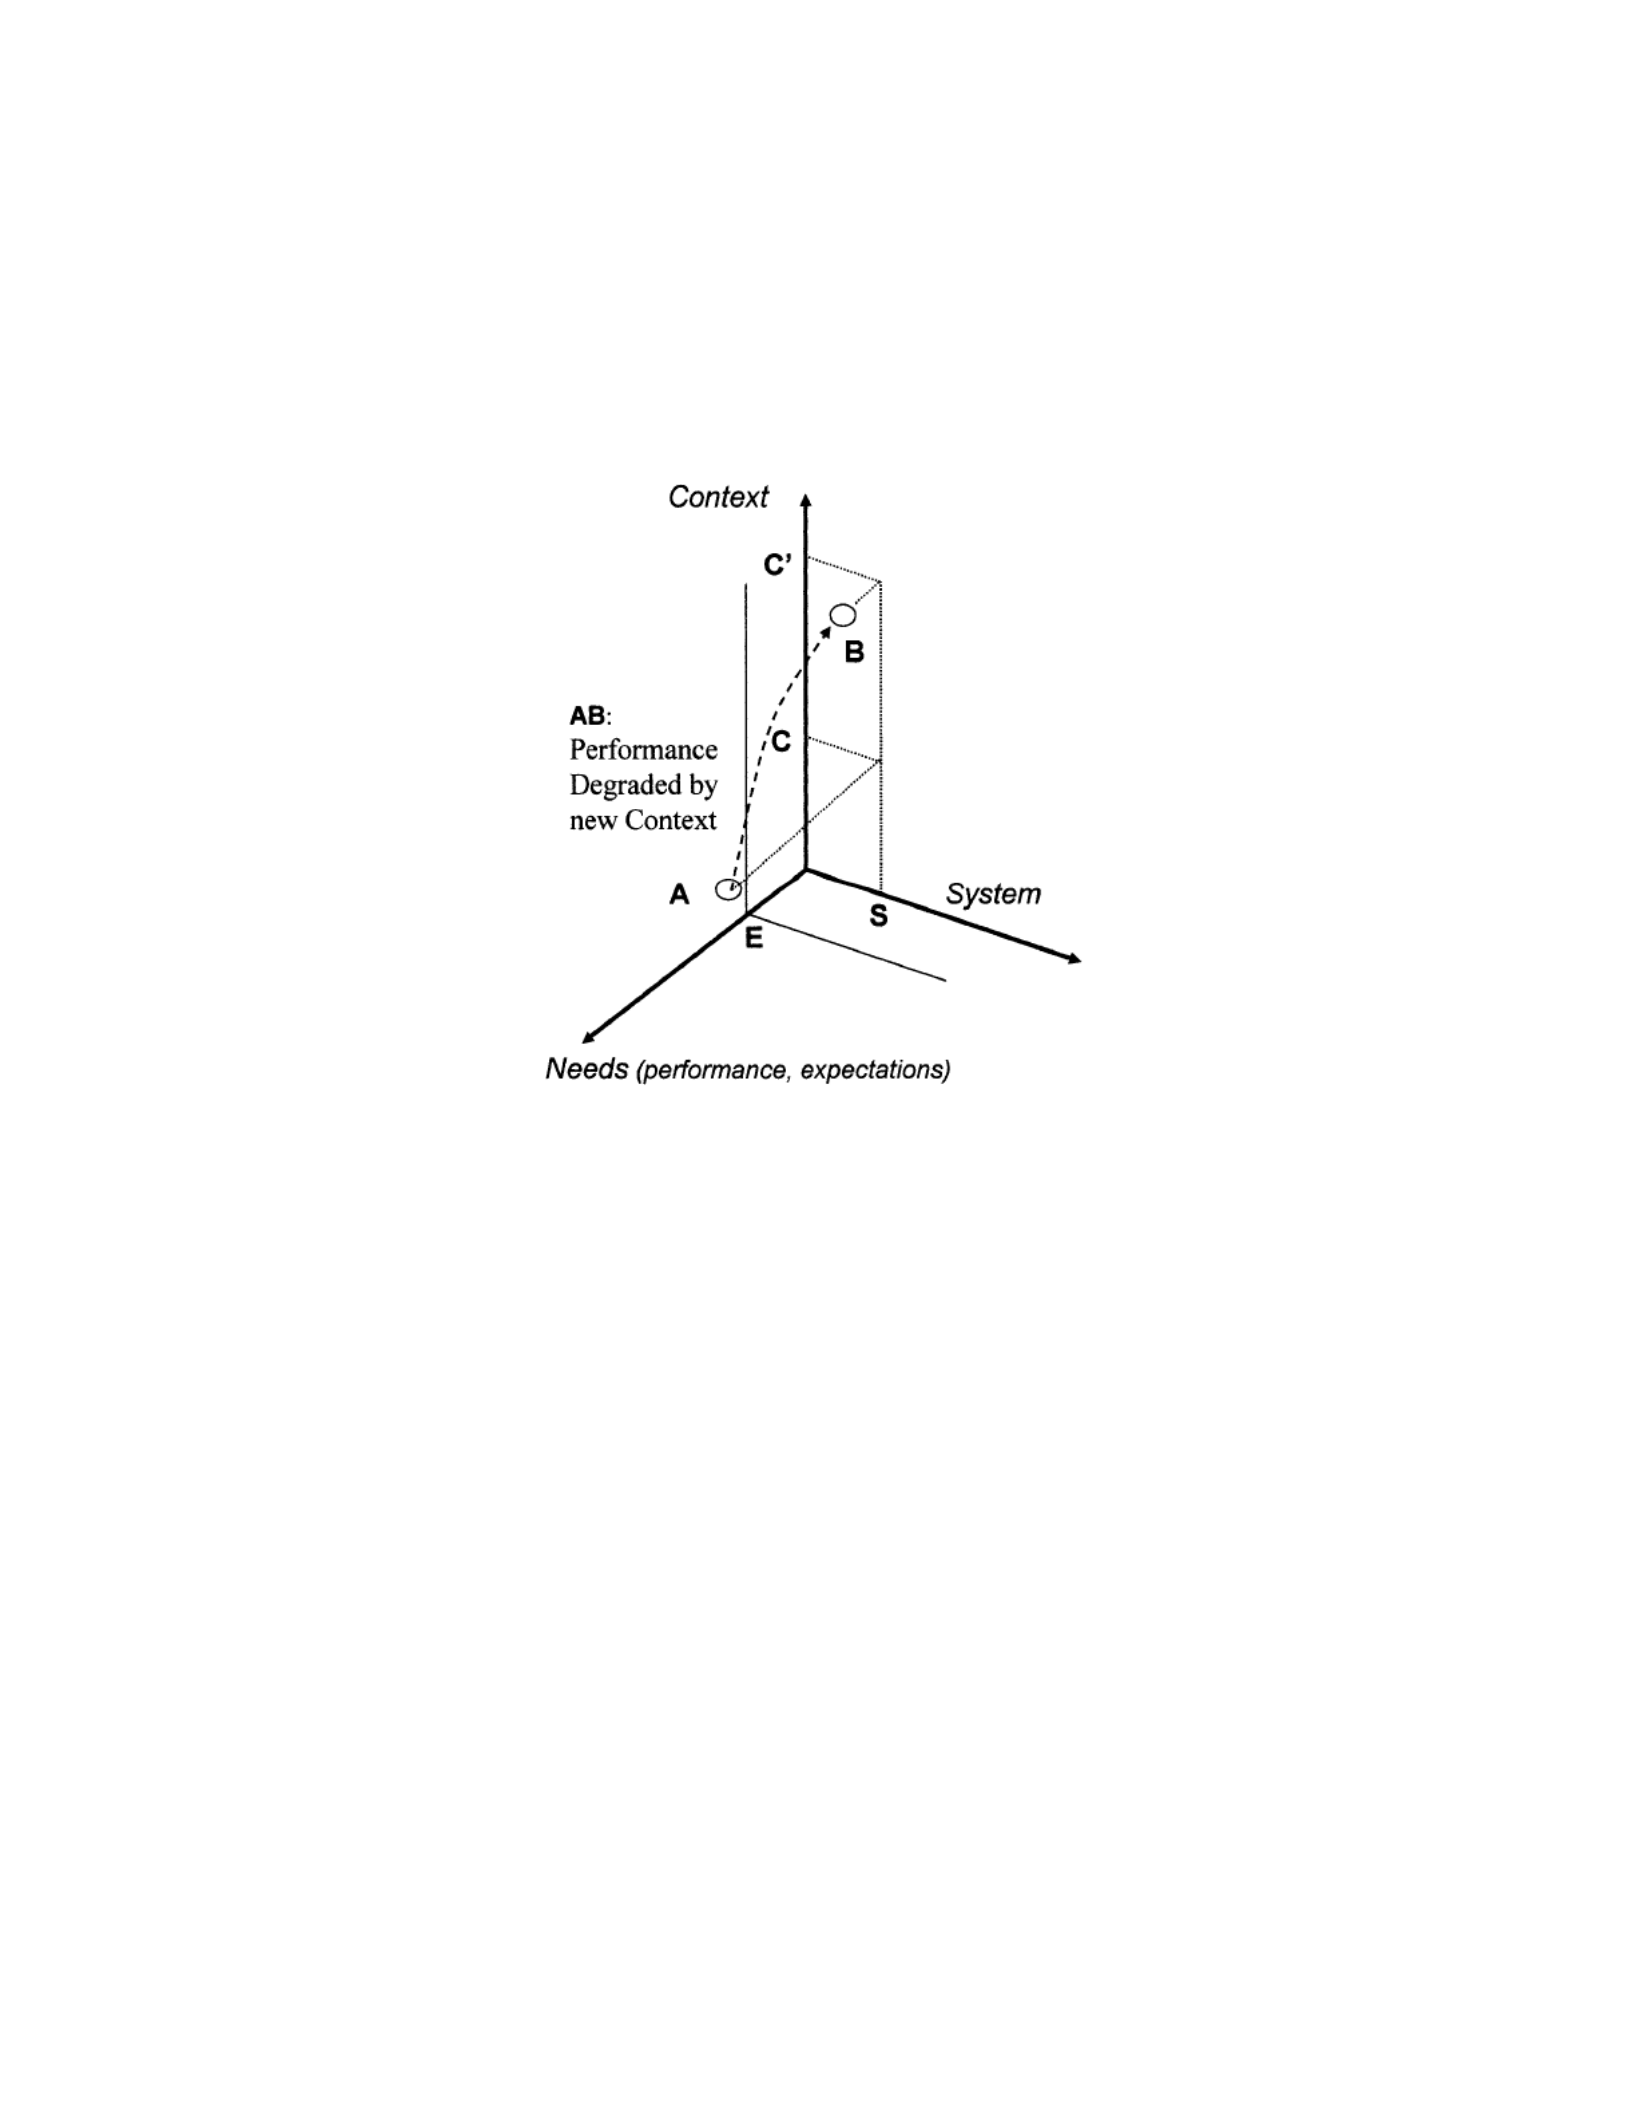
the presence of change." The authors emphasize that ility is dynamic, based on changes in the
needs of the system, the system itself, or the context of the system, as depicted in Figure 4.
Survivability is defined as "the ability of a system to minimize the impact of a limited duration
disruption on value delivery, which is achieved through (I) reduction in the likelihood or
magnitude of the impairment, (II) satisfaction of a minimally acceptable level of value delivery
during and after the disruption, and/or (III) timely recovery." The authors distinguish resilience
from resilience, although both are "measures of a system's ability to reduce the sensitivity of
their output to environmental changes." In this way, resilience is considered a case of resilience,
16
in which the system must mitigate limited changes in the context or impulse events. An eight-
phase multi-attribute commerce space exploration for the survival process is presented, with
measurable metrics of the end of the time-weighted average utility loss and threshold
availability.
Figure 4: Context-density configuration requirements space (Richards, Ross, Hastings, &
Rhodes, 2009)
(Doerry & Moniri, 2013) cites the need to improve the survivability and reliability of naval
and energy power systems as systems evolve from traditional low-voltage systems to meet the
demands of new high-power combat systems.
2.2 Design Metrics
To evaluate alternative power and energy system architectures, (Smart, et al., 2017)
identified the need for metrics to differentiate between design alternatives. The study explores
the impact of new technologies and alternative topologies. Several metrics are available in the
designated design tool, S3D, including weight, volume, number of components, and calculation

17
of fuel load range. The authors propose several future areas for development in early-stage
design tools, including a variety of performance metrics.
(Toshon, et al., 2017) presents a method for executing Set-Based Design in on-board power
systems using the metrics available in the early-stage design tools. The authors discussed the
topology of the 5 MW Modular Multilevel Converter (MMC) and identified related metrics
related to thermal facility selection, power density, and cabinet size as selection criteria for the
preferred architecture.
(McNabb, et al., 2019) presents a case study to measure the architectural value of a
particular electric vessel within a broader trading space using a methodical approach to apply
architectural variations in the base model in a robust design simulation environment. The
example presents the basic performance metrics measured, displacement, speed, and range
variation.
(Chalfant, Hanthorn, & Chryssostomidis, 2012) discusses some of the metrics commonly
used in the design analysis of early-stage P&E systems of alternatives, such as weight, volume,
fuel efficiency, and losses (based on location, size, and loading). They present additional
survival metrics, which depend on input data from the load, defined services, connectors, and
their associated locations. These metrics and the underlying variables are identified in existing
design tools, as they are necessary to define the physical architecture and functional
capabilities of the system.
2.2.1 Measures of Effectiveness
At the beginning of this literature review, the initial theory was that there was a relationship
between the method used to determine the system's utility, the overall effectiveness measure
(OMOE), and illiteracy. A common relationship found between different ways of setting design

18
priorities is to use scenario-based evaluation to derive alternative value of the system.
(Berrow, Parsons, Shane, Kara, & Brown, 2022) presents a method for performing mission
capability modeling, which requires an interface between logical-operational-physical
architectures. This analysis relies on the determination of Measures of Effectiveness (MOE),
Measures of Performance (MOP), and Design Reference Missions (DRM). The authors define
MOE as the metric assigned to each mission that is evaluated to quantitatively or qualitatively
measure how well a task is completed and MOP as a metric to characterize how well a task is
performed by the capabilities that make it possible. DRM is a specific set of scenarios and
operational requirements that are used to determine the overall measure of effectiveness when
comparing early-stage design concept architectures.
(Mierzwicki & Brown, 2004) identified a two-phase approach to conducting a risk
assessment for comparison with cost and performance in the evaluation of multi-attribute
designs. The Overall Risk Measure (OMOR), depending on the design variables, is proposed for
the exploration of the concept at an early stage. Variable risk is based on expert opinion and is
related to performance, cost, and schedule. The accompanying quantitative Overall Effectiveness
measure is determined based on the design variables and the specified mission thresholds and
objectives. The probability of success is referred to as robustness. The second phase is presented
for the later stages of concept development when a higher fidelity evaluation is required,
utilizing the risk probability distribution function.
(Bottero & Gualeni, 2022) discusses the application of systems thinking in the design
process of traditional naval architecture. They propose a capability-based approach, in which the
ship's functions (representative focus on the required systems) are outlined from Key
Performance Parameters (ship functions), High-Level MOPs (ship-level), Low-Level MOPS

19
(system-level), and TPM (parameters).
(Goodfriend & Brown, 2018) proposes an Overall Vulnerability Size (OMOV) that is
incorporated into an existing design space evaluation tool called the Multi-Objective Genetic
Optimization (MOGO) framework. OMOV relies on the identification and prioritization of vital
components (VCs), the location of VCs within the geometry of the gastric compartment, and
probabilistic vulnerability analysis. Statistical component factors in the type of threat, the
location of the potential hit, the probability of killing the VC in the event of a hit, and the
probability of killing the system given the aggregate assessment of equipment deactivation after
damage.
2.3 Space Exploration Design Methods
A repetitive set of terminology is found throughout the literature review on systemic
diseases. To build on the same colloquial language, the various approaches to implementing
ilities to maintain system value generally refer to "options in design", "distractions", and
"Preparation." To design unity and to maintain system values, the term disruption is used to
characterize the influence on a system that requires change. Design options are the ability
inherent in design to accommodate future changes. They give the system owner the option or
right to implement changes later in the system's lifetime once a need has been identified (the
right to take action). Preparation refers to specific architectural features or capabilities that are
planned into the design to enable the system to respond positively to disruptions (maintaining
value, cost value, effectiveness).
(Ricci, Fitzgerald, Ross, & Rhodes, 2014) defines disruption as "an undesirable (i.e.,
imposed) change in circumstances in the design, context, or needs of system stakeholders that
can

20
jeopardize value delivery;" and options as "the ability to execute design decisions or features
at any point in the lifecycle that would change or prevent changes to the SoS, in response to
variations in the operational context and stakeholder preferences." The author further breaks
down the options into change options, which allow changes in the design in response to
disturbances, and resistance options, which increase the system's ability to withstand the effects
of changes from disturbances.
(Mekdeci, Ross, Rhodes, & Hastings, 2012) decomposes disorders into disorders and
disorders in their "Taxonomy of Disorders of Disorders". Disorders and disorders are defined as
a type of disorder, with the difference that the disorder occurs over a period of time, but the
disorder is almost instantaneous.
The following sections discuss some of the current methods used to characterize
architectural value or alternative system decisions in early-stage design. The end-to-end design
process relies on a large number of architectural decisions that require data and an
understanding of the trade-offs between design alternatives. There are several effective methods
for conducting these alternative comparisons, including exploration of design spaces and set-
based designs. In addition to identifying system value in the face of changing contexts and
requirements, the various methods discussed below rely on the designer's ability to define
system boundaries.
2.3.1 Causal Mapping
(Hein, 2022) presents a framework for identifying and characterizing flexibility in design
using Causal Mapping (CEM) or cause-and-effect chains. This approach uses key distractions,
preparations, and option elements to provide designers with insight into the value of flexibility.

21
Hein suggests proper characterization of the disorder such as risk assessment, which uses the
elements of likelihood and severity to describe the potential event. Within the framework,
preparations are tied directly back to the distractions they want to reduce and
characterized by cost and complexity. The authors define preparation as "something that can be
done in the present that mitigates, eliminates, or allows the option to reduce or eliminate the
negative effects of future events." This paper identifies six essential principles for identifying
appropriate disturbances, including the definition of system ownership (affected systems),
organization, and the concept of immediate external disturbances (IEPs). IEPs are useful in
determining the scope of direct impact on the system of interest. They can be categorized as
changes in the mission, changes in the projected operational environment, changes in
capabilities, or non-technical decisions. No metrics are presented to prioritize or determine the
value of each preparation, including any relationship back to possibility.
(Mekdeci, Ross, Rhodes, & Hastings, 2012) outlines the process for performing cause-and-
effect mapping to obtain unknown-unknown disturbances effectively. In its application, cause-
and-effect mapping considers the context of the system, the Concept of Operation (CONOPS),
and the chain reaction of the disorder so that the system architect can categorize and address the
identified effects. The resulting taxonomy defines the categories of value loss associated with the
type of disorder: loss of capability, degradation of capability, change in mode of operation,
increased cost, or change in stakeholder expectations. The discussion of value robustness is
presented in the context of system survival, broken down into aspects of prevention, mitigation,
and recovery.
2.3.2 Differential Analysis
(Ricci, Fitzgerald, Ross, & Rhodes, 2014) Present the System-of-System Architecting with

22
Ilities method to measure the tradeoffs between design options required to target specific ilities,
resulting in customized system requirements. The eight-step process is laid out in detail, starting
from the initial definition of system requirements and value determination, the identification of
potential faults to obtain the desired system faults, and the creation of alternative architectures
with ilities in mind. Identify the disruptions organized into fixed time periods, called epochs, to
categorize the context of the system and how its changes will affect the SoS value.
In SAI, desired ilities are identified after surveying potential SoS disruptions and
stakeholder needs. Evaluation of different options describes the desired problem, providing a
contingent value if a disturbance materializes. The logical flow of research is a method for
uncovering diseases and metrics.
(Guariniello & DeLaurentis, 2014) shows that some sets of ilities have competing interests
and effects on the design, architecture, and evolution of system systems. They propose a
framework to conduct a trade-off analysis that combines elements of functional dependency
network analysis (FDNA) and development dependency network analysis (DDNA) to assess the
impact of both types of dependency on ilitas. The disease is measured in terms of operation over
time, as assessed against various developmental and disorder scenarios.

23
An important utility of this analysis is the ability to model and account for partial capabilities in
the SoS development process. Robustness is assessed in mission scenarios when some loss of
capability has occurred, robustness is considered when disruption occurs, and partial capability
can be restored due to system interoperability. Flexibility is evaluated in the context of the
development cycle, which requires mission coverage from other connected systems within the
SoS.
(McNabb, et al., 2019) presented the Technology Identification, Evaluation, and Selection
(TIES) methodology to identify system sacrifices and assess designs against "Merit Numbers."
In this methodology, technology evaluation relies on the simulation environment to determine
the impact of probabilistic design parameters. Through a discussion of case studies to measure
the architectural value of a particular electric vessel within a broader trading space, the authors
outline the Technique for Preferred Order (TOPSIS) as a means to conduct Multi-Attribute
Decision Making (MADM), which is a weighted means of identifying the best or worst designs
in a given trading space.
2.3.3 Scenario-Based Evaluation
(Chalfant, Hanthorn, & Chryssostomidis, 2012) presents a method to analyze the topology
of the electric ship distribution system based on two ways of assessing the survival of the
system. This approach involves determining the priority rating of serviceable loads and specified
services, connectors, and locations. The first score determines the overall ability to provide and
distribute power after a breakdown based on the weighted priority amount of the remaining load
and the amount of power or capacity of other resources, such as cooling capacity, delivered to
that load. This approach requires establishing a damage case scenario or a series of damage
cases based on the assumption of the explosion profile. These cases can be explicitly regulated

24
or stochastic-defined. The second metric is used to characterize the severity of the damage by
identifying the highest priority load that cannot be filled, following the same analysis method for
the first metric.
(Chalfant & Chryssostomidis, 2011) presents a relatively simple application of the
operational profile for a ship's powertrain and energy system based on the percentage of time per
year the platform spends on each combination of speed and electrical load. This data, combined
with the characteristics of the system components for propulsion and power generation, makes it
possible to calculate the fuel consumption profile based on conditions.
(Chin, Yau, Kok Wah, & Khiang, 2013) presents an example of a system resilience
evaluation by defining a series of scenarios to test the ability of the SoS to meet its operational
requirements, with the analysis presented as a Measure of Effectiveness
(Cramer, Sudhoff, & Zivi, 2007) defines a method for determining the continuity of service
metrics to predict worst-case scenarios for the survival of layered systems, such as power and
energy systems. This technique involves the definition of "event" (cross-product of the external
environment, IEP configuration, and possible interference) and "operation-

25
metric" (continuity of service for vital loads given the requirements of time-dependent
scenarios).
(Stevens, Opilia, Cramer, & Zivi, 2015) presents a method for establishing operational
sketches to assess electric ship power and energy systems. The sketch is defined based on the
sequence of stochastic load modeling under cruising and combat conditions and operational
propulsion scenarios over a given period. Implementing this method requires a notional or basic
power system architecture, including propulsion, power generation, complete load sets
- Integrated load parameters (max/min power rating, ramp rate, pulse width, repeat), and spatial
(zone) settings. Stochastic modeling of various mission load power demands is presented for
pulse load number, unit power level, and pulse length. This method makes it possible to
evaluate the architecture and topology of different high-level systems.
(Sabah, Ojo, & Cramer, 2021) describes an operability-based performance metric as the
ability of a system to work in a single scenario, given combat damage, unique load profiles,
cyber interference, and others. The authors emphasize the unique demand profile of electric
warships for "dynamic" capability, to perform relatively short-duration missions as a reason to
support a shift in focus from load-centric operations (linear power flow) in early-stage design to
mission-centric (nonlinear relationships between resources and mission effectiveness). The
authors present an example of an evaluation of three system configurations (energy storage
differences) and expected performance across three different mission scenarios to obtain a
probability of successful performance.
In the development of a framework for assessing the flexibility of naval warships, (Doerry
& Koenig, 2017) proposed a method for defining "uncertainty vectors" to assess the
performance of flexible design trading spaces over time. The uncertainty vector is
26
It is configured to capture a series of scenarios at different points in the projected lifetime of the
system and contains a variety of assessment criteria related to potential changes in requirements
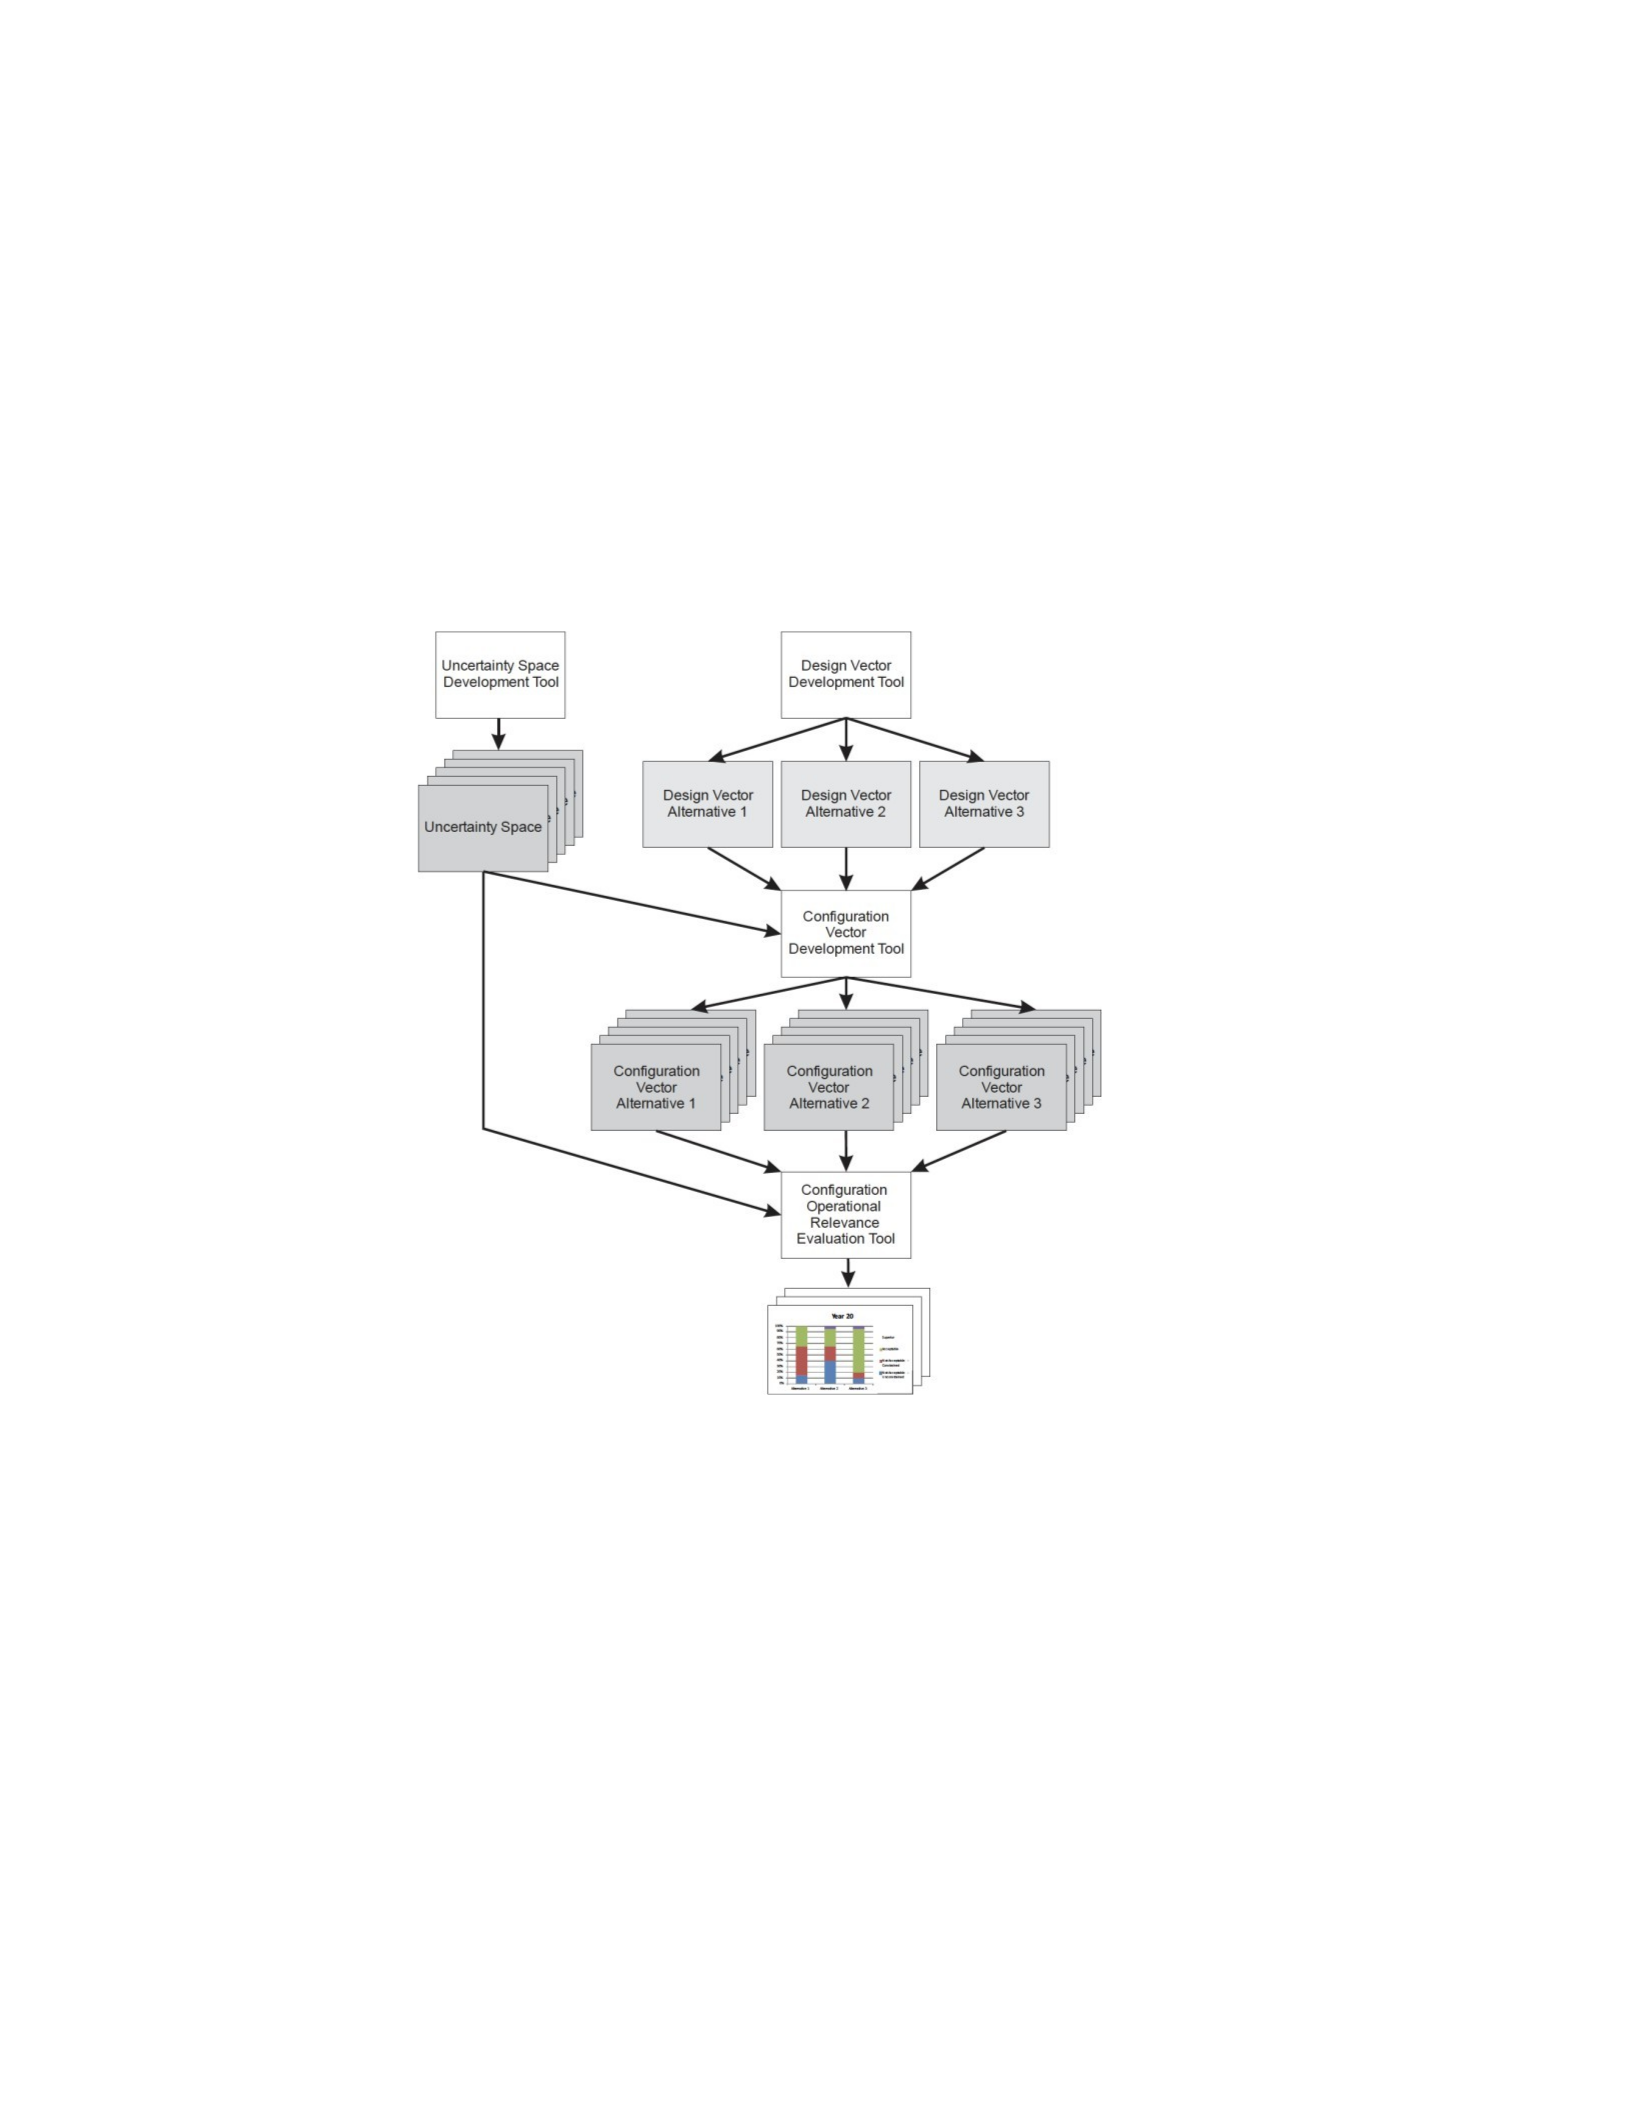
for combat capability and technological maturity. The state of uncertainty, or the combination
of uncertainty parameters in a vector at a given time step, can be fixed or determined
stochasticly. The proposed framework is depicted in Figure 5, showing how uncertainty space
is used to evaluate design vectors and configuration vectors.
Figure 5: Framework for assessing flexible design (Doerry & Koenig, 2017)
2.4 System View & Context
Naval power and energy systems are complex, multidimensional systems, including
architectures that perform a variety of tasks related to the generation and supply of electric
power, cooling, and mechanical utilities, among others. In the literature review, ilities are
discussed in the context of individual components of multifaceted systems and in high-level

27
integrated systems. The traditional design process focuses on optimizing specific system
domains depending on the requirements and priorities of the desired system. (Brefort, et al.,
2018) claim, "The growth of system complexity and interdependencies has made systems
significantly more difficult to understand and design, in part due to an increase in potential
emerging properties that only emerge after the system is completed and operational."
(Brefort, et al., 2018) presents a framework for analyzing the distributed systems of naval
ship design by outlining the characteristics of the systems into three main architectures: physical,
logical, and operational. The relationship between interconnected and interdependent systems is
discussed in terms of their spatial, functional, and temporal characteristics. The framework
intends to provide deeper insights into complex systems, such as integrated power systems, in
the early design stages. The authors present this framework with specific survivability in mind
but outlines its applicability for other desirable system characteristics. The different properties of
the three main architectures traditionally produce different types of information that require
many devices The author defines the main architecture as follows:
Physical architecture represents the spatial and physical characteristics of a system
and its environment.
Logical architecture describes the functional characteristics of the system and the
relationships between each component of the system. Logical architecture is where the
main focus is placed on the multidisciplinary nature of the system.
Operational architecture describes the temporal behavior of a system, including
human-system interaction to some extent.
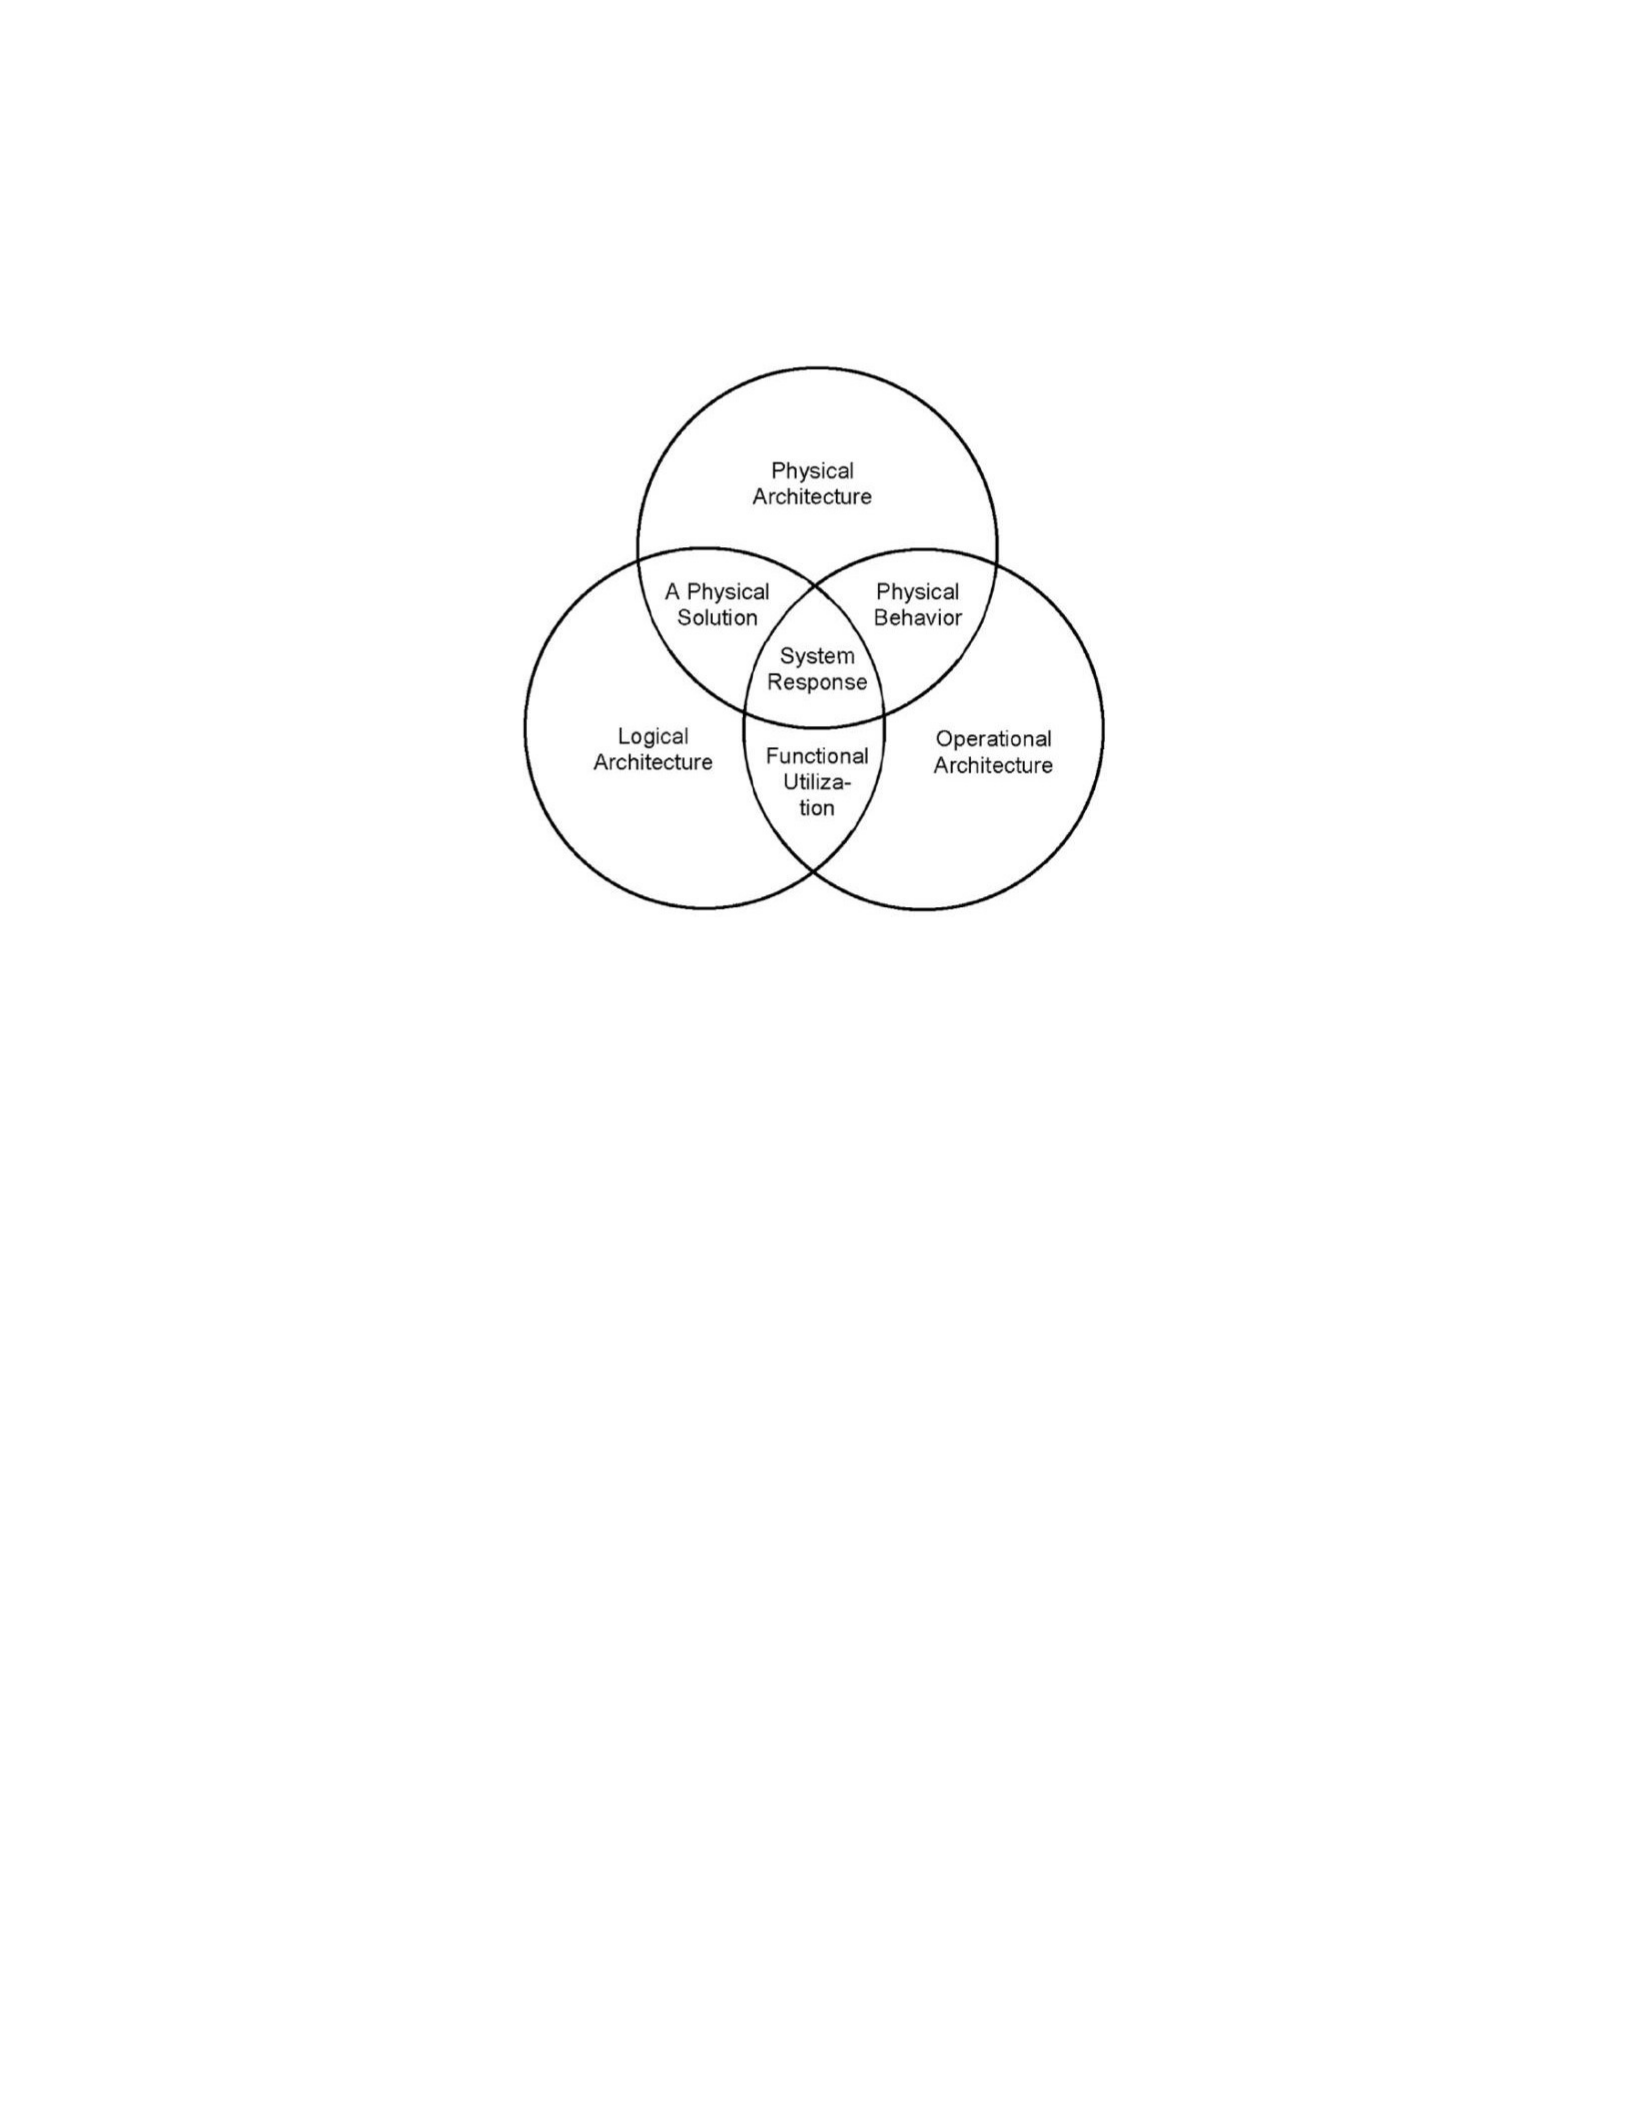
Figure 6 illustrates three main architectures and their interrelated: physical solutions,
functional utilization, physical behavior, and system response. These overlapping areas
28
combine information from each major architecture to provide a deeper understanding of the
design space.
Figure 6: Representation of the physical-logical-operational framework for a given scenario
(Brefort, et al., 2018)
(Cramer, Sudhoff, & Zivi, 2007) introduced the Integrated Engineering Plant as a system
that provides electric power, mobility, and thermal services. The authors define a method for
determining the continuity of service metrics to predict worst-case scenarios for system survival.
A layered approach is outlined for Integrated Engineering Plants, including spatial, automation,
air conditioning, DC, seawater, and thermal layers to capture the behavior and functionality of
each component. The framework for assessing survivability involves determining "events" and
"operations" to generate metrics, including average operation and minimum system
dependencies.
(Jansen, et al., 2020), in their discussion of the early-stage ship design vulnerability

29
assessment approach, differentiated between two types of system models for distributed system
design: a physically oriented ship perspective and an operationally-oriented systems
perspective. This perspective provides a logical, operational, and physical description of a
distributed system. The systems perspective defines the topology of interrelated elements and
focuses on values such as capacity, flow, and thermodynamics (load balancing). The topology
is defined by vertices and edges that represent the main elements and their logical relationships.
The ship perspective focuses on the physical integration within the ship, including system
routing (balancing mass and volume). The methods for assessing vulnerability are organized
based on phase and design perspective: max-flow-between-hubs (energy flow, deterministic,
large # nodes), Markov (state/transition/capacity, probabilistic, small # nodes), and hurt-state-
percolation (damage cases/scenarios, deterministic, large # nodes).
2.5 Ility - Flexibility
Flexibility was found to be the dominant obstacle considered throughout the literature review.
As discussed in Section 2.1, flexibility is often presented along with the classic weaknesses of
survival and security as a mechanism to easily enable system changes in response to different
types of disruptions. In the community of naval power and energy systems, the desire for system
flexibility is clear; However, only one accepted approach to implementation currently exists.
Unlike survivability, where industry, government, and Navy-specific guidance has been issued
to define system requirements, flexibility is still in the early stages of definition and
implementation. This is partly due to the wide scope of system requirements and attributes that
are generally categorized as flexibility. Where the definition of survival is widely accepted as
outlined into vulnerability, vulnerability, and recovery, the literature on flexibility ranges from
intrinsic design properties to tangible options for stakeholder value.

30
(Chin, Yau, Kok Wah, & Khiang, 2013) defines flexibility as "the degree of ease with which
an SoS can make changes, in response to external or internal changes, in order to maintain the
effectiveness of its mission." They suggest that there are two different types of flexibility –
operational: the ability to transition between different modes of operation, and design: a design
attribute that allows the system to incorporate changes more easily. Agility, adaptability, and
scalability are considered part of flexibility.
(Hein, 2022) defines flexibility as "a measure of a ship's ability to scale up quickly and
cheaply to respond efficiently to known or unknown disturbances." His thesis develops a
framework for identifying and characterizing flexibility in design through cause-and-effect
mapping.
(Doerry, 2014) identifies eight methods for global ship flexibility and how electric power
distribution systems should be considered in each approach. This flexibility approach includes
the arrangement of physical onboard equipment to align with hull and electrical zone features,
longitudinal electrical distribution bus sizing, power cable sizing, use of interface standards for
supporting equipment, use of Integrated Power Node Centers (IPNC) to convert power for end
users, Electronic Modular Enclosures to isolate commercial equipment and provide power and
conversion conditions, and incorporation of energy storage methods. Doerry specifically
highlighted the importance of flexibility in electrical distribution systems to serve future electric
weapon systems with much higher power ratings and load-type demands and proposed several
interfaces to be developed, including the required power

31
type, amount of power required, ramp level, power quality, service quality requirements, and
monitoring and control conditions. The Traditional Service Life Allowance (SLA) is discussed
from the perspective of the Interface Control Document. The authors suggest that these
documents need to define the explicit intent of a specific SLA.
(Doerry & Koenig, 2017) proposes a framework to identify what type and amount of
flexibility will "enhance the ship's ability to reconfigure quickly and economically in the future."
They recognize the temporal aspect of the necessary change as temporary mission capabilities or
permanent reconfigurations. Their paper discusses modularity, adaptability, and flexibility as
pertaining to specific types of technologies that can be combined, each with an independent
impact on the overall affordability of the system. The need for flexibility over the platform's
lifetime is based on the potential for unknown changes in requirements, including high power
and new variant combat systems and missions. The overarching framework is based on the
principles of Real Options analysis, where design options are considered in relation to the cost
per value given. In early-stage design and requirements formulation, this type of analysis is
invaluable for estimating potential changes to system requirements and evaluating cost-effective
means of responding in the future, but requires upfront investment in design. The authors define
a trading space of the type and quantity of modular and adaptable technology, taking into
account the cost impact in terms of weight/space/design effort. The technology for this flexible
vessel is proposed by considering the location of the future system, power capacity, sufficient
power conversion and distribution, and cooling capacity to support the future system.
(Page J., 2012) discusses the value of flexibility options in the design of early-stage naval
warships rather than options on projects or designs. The authors argue that the analysis of Real
Options and Net Present Value (NPV) needs to be modified to evaluate capital projects (without

32
income) and options in design based on needs, costs, and capabilities. The authors identify power
generation and power distribution as the top design considerations for considerations that allow
for the upgrade of historical ship platforms, following general arrangements. Given the Navy's
budgeting constraints that limit investment in new capabilities through the development of new
ship classes, the framework is presented using the Overall Effectiveness Scale based on the
Preferred Model of how capabilities can be added to a single ship class over time. This example
compares an inflexible platform (the current Navy) to a notional modular platform with some
flexible preparation. The authors suggest extending this framework to the subsystem level or
SoS-level analysis. The paper also points out that flexible platforms have lower upfront
acquisition costs, contrary to many discussions about flexibility costs.
(McCauley, Hannapel, Bassler, & Koleser, 2016) introduced the concept of "SWAP Boxes"
to separate the ship's payload (combat system) from the platform. This decoupling is intended to
counteract the tendency observed in the Navy's design program to quickly lock in design
requirements to reduce design time and limit the weight of the ship to control costs. The authors
state that flexibility and modularity are two concepts: "flexibility is the ability of a ship's design
to Accommodating the growth of combat systems, and the ability to incorporate new
technologies into ships throughout the life cycle of each ship and its class. Modularity is the
ability of a platform to accept a system as a standalone unit with a standard interface." They
define flexibility as a function of four criteria: design flexibility, construction modularity,
mission modularity, and mission flexibility. Some of the key benefits of implementing the
SWAP Box approach are the ability to apply targeted system margins versus top-level margins
and the ability to perform sensitivity analysis against the intended system maturity. For impacts
on power and energy systems, the SWAP Box parameters will include mission-related loads
used to measure distributed systems; However, this method clearly does not apply to the

33
architectural design of the power and energy system itself.
3Problem Statement
A published review of the material has identified several key elements of the SoS ilities for
further refinement and implementation in the Navy's power and energy system design process.
The Navy design community needs a consistent method for evaluating non-functional
requirements at the initial design stage, when informed decision-making provides the greatest
opportunity to positively impact system performance and lifecycle costs. This research proposes
a framework to develop metrics that can be used to identify preferred options with design
spaces. The proposed process is undertaken to develop quantitative and measurable metrics for
the flexibility of the Navy's energy and power systems, a non-functional requirement that
appeals to the design and acquisition community but lacks a common understanding base. This
research and its implementation are framed by a problem statement:
To measure non-functional requirements for early-stage design decision-making
By developing metrics for the Navy's power and energy system Flexibility
Use the framework to characterize potential disruptions that affect system changes and
measure the value of potential design options in terms of the physical, logical, and
operational impact of the system.
4Research Summary
This study presents a hierarchy of ility relationships for naval power and energy systems
and proposes a framework to outline top-level requirements and ility-based requirements into
metrics to identify the dominant architecture in the early-stage design trade space. The
framework considers the physical, logical, and operational aspects of

34
to generate a series of disturbances that are likely to affect the system's ability to
maintain value throughout its life cycle. Choosing a preferred architecture requires balance
between uncertainty, performance, cost, and complexity for the "right size" of the system. A
deep dive into Flexibility, of general interest, is presented with four case studies using proposed
metrics for power and energy system flexibility. This work is intended to present a repeatable
process for developing metrics that can be integrated in early-stage design tools to generate and
evaluate naval power and energy systems.
4.1 Ility Relationship
The collection of research presented in the literature review shows a general definition of
ilities as an emerging system property that affects the system's ability to retain value over time.
Ilities are not primary functional requirements, as defined in the Initial Capability Document or
Capability Development Document that define the system's objectives, but rather attributes used
to measure the system's ability to respond to change.
Emergent refers to the functions or capabilities that are generated when multiple elements of a
decomposed system architecture are integrated together. While the design community agrees on
perceived value in analyzing ility, system architects and decision-makers need a consistent
method for prioritizing and measuring ility requirements. The U.S. Navy Guide identifies the
need to assess issues such as reliability, maintenance, sustainability, flexibility, and
vulnerability. The Vessel Specification will typically detail the expected productivity,
operation, and maintenance of the vessel. However, this propriety is usually measured in the
final stages of design, after the ability to influence the architecture of the system has passed. An
upfront understanding of dependencies and the relationship between functional needs and
requirements will allow designers to identify stronger solutions when making architectural
decisions in the early stages of design.

35
This study investigates the relationship between systemic diseases and underlying
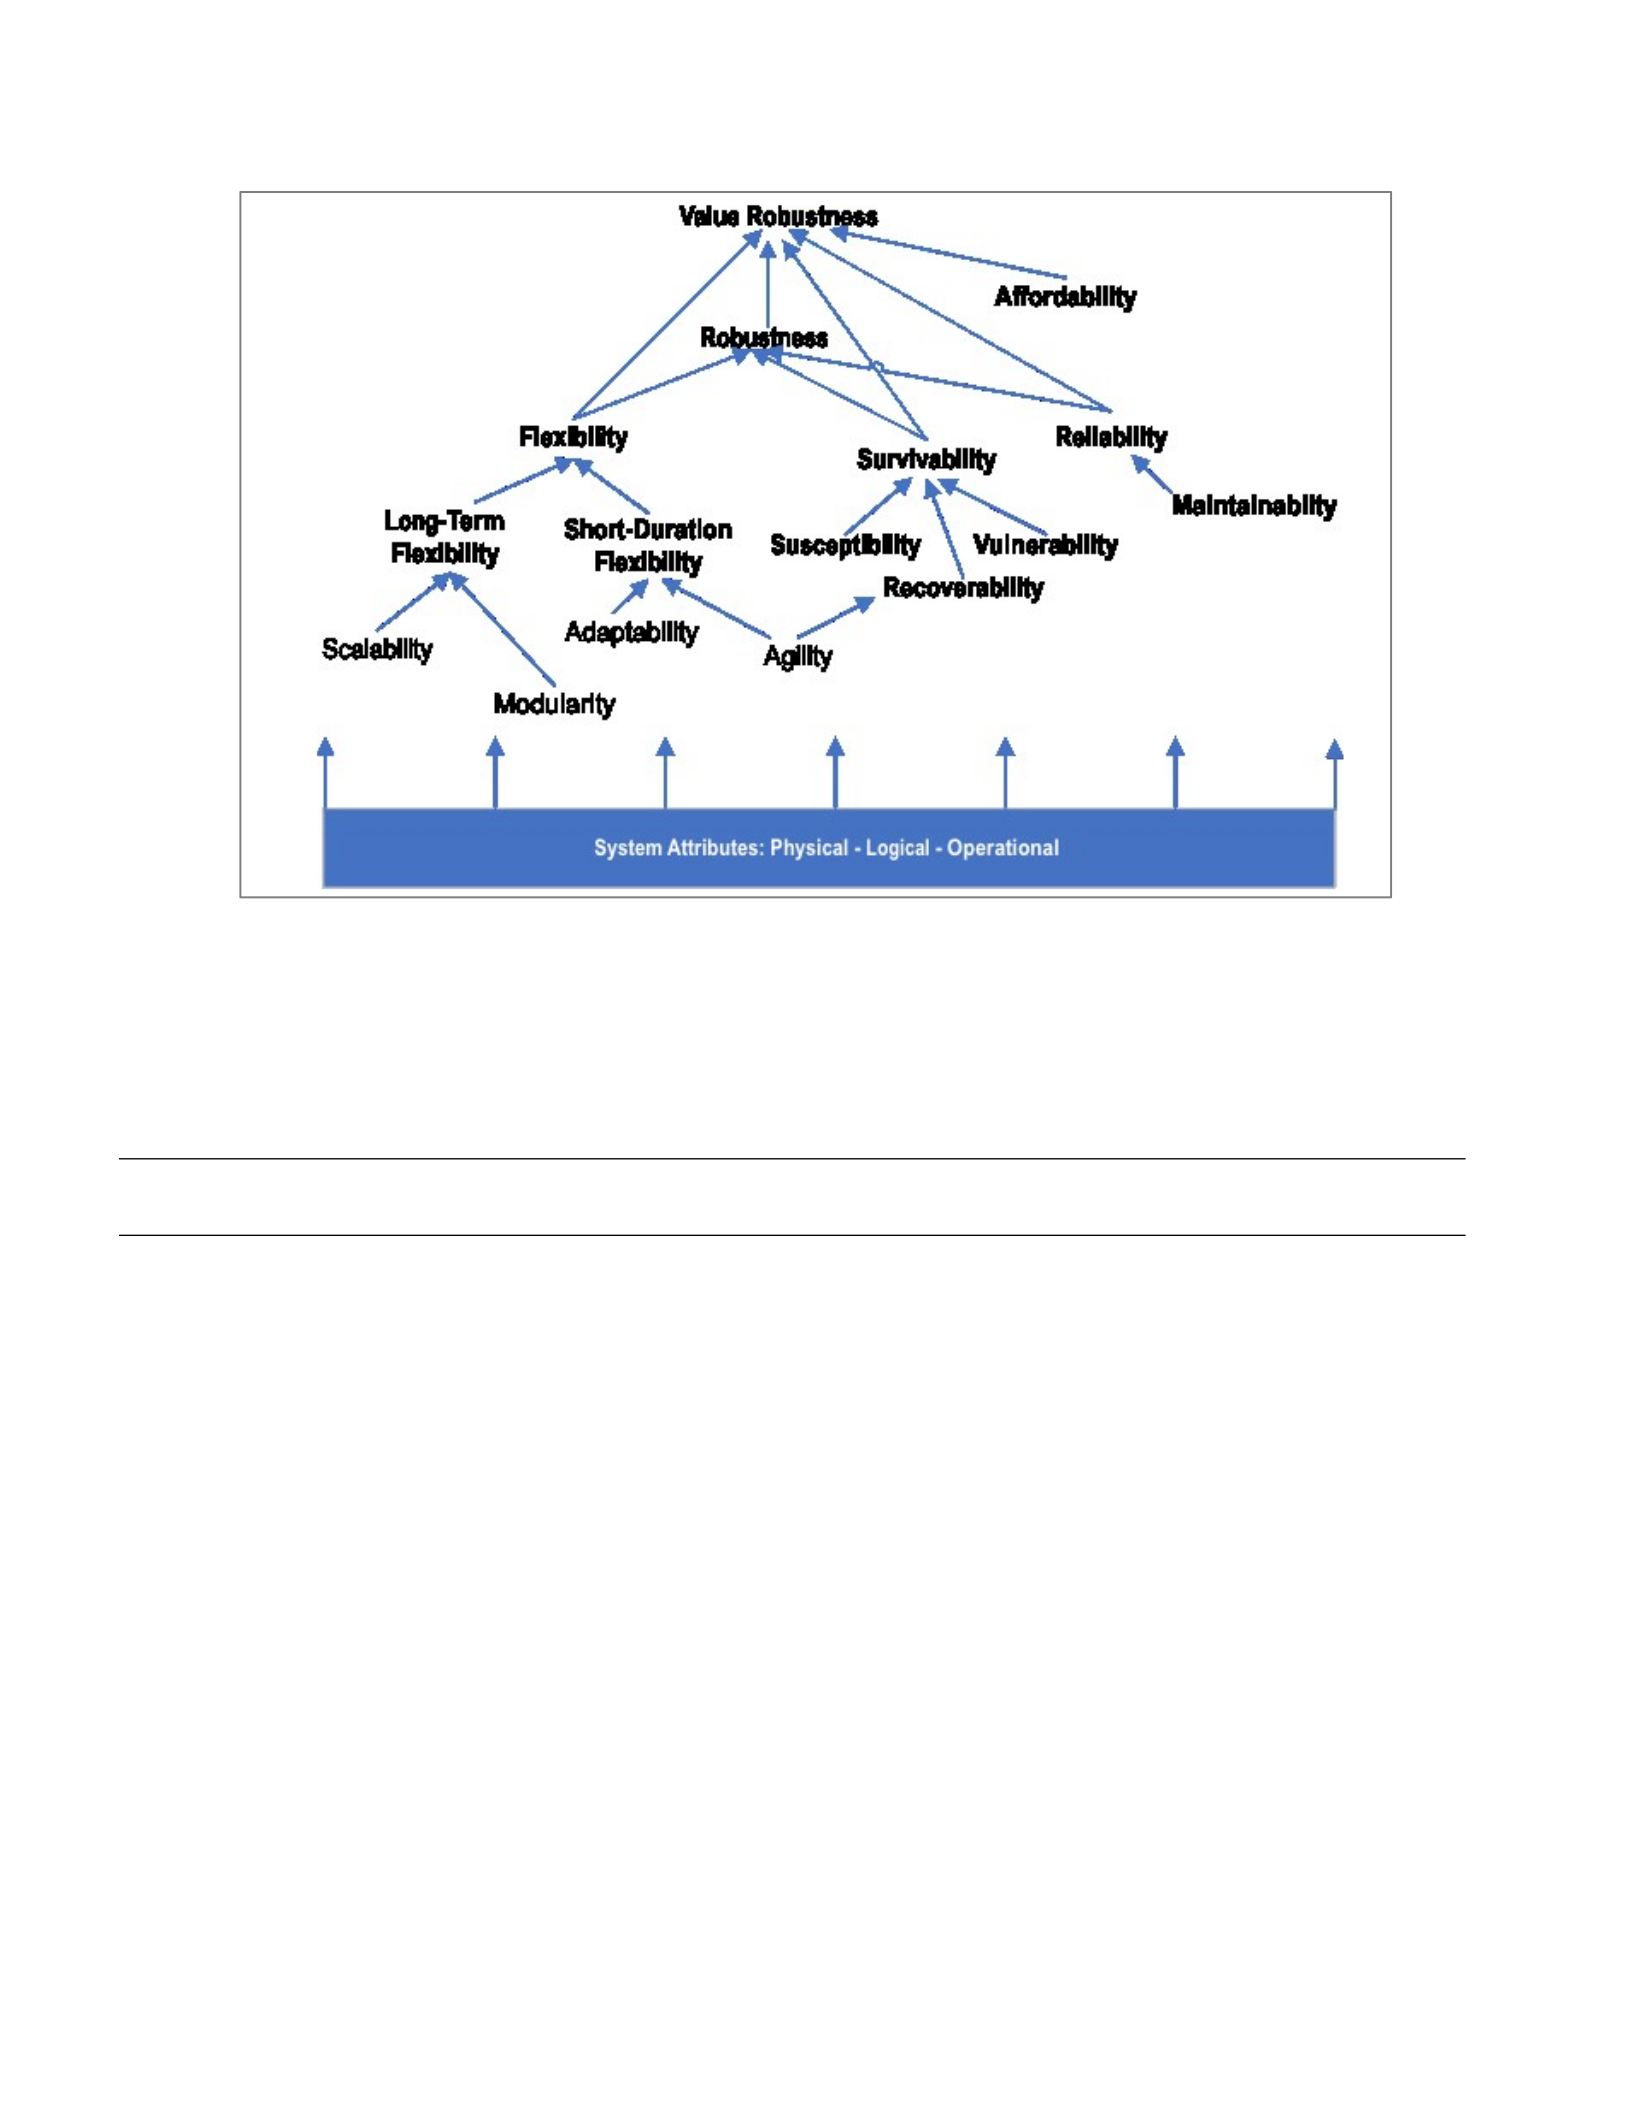
characteristics that may be common to certain types or families of diseases. Figure 7 illustrates
the ilities hierarchy for the Navy's power and energy systems, based on the end-of-the-road
approach presented by de Weck, et al. (2012). Of course there are more diseases than are
depicted, but this representation is meant to focus on things that are significant to maintain the
value of the power and energy system. The final average approach is represented by an arrow
directed upwards from the lower level condition that allows the above attributes. The overall
purpose of the ility hierarchy is to enable Solidity Value, or retention of value under the
influence of change. At the base of the hierarchy are the physical, logical, and operational
attributes of the system that serve as the basis for the properties that emerge, as discussed in
Section 5.1. The next part of the study will focus specifically on Flexibility as a priority system
property due to the current rate of change in the functional demands on the P&E system.
36
Figure 7: "Ility" hierarchy of power &
energy systems Table 1. Definition of
ility
Perseverance The ability of a system to...
Adaptation to be changed by the system's internal change agent with intent*
Affordability to minimize acquisition and lifecycle costs to maintain value
Agility to be changed in time*
Flexibility to make changes in the system in response to interference
Note: Flexibility is further elaborated based on temporal responses, as defined in
Section 5.
Maintainability to be maintained regularly so that failure does not occur.
Modularitas consists of modules (at various levels of module composition)
Recovery to restore the system in a timely manner (with various measures of timeliness)**
Reliability to operate without problems, as measured over a period of time
37
Resistance to maintain a defined level and/or set of parameters in the context of changes in the
internal and external forces of the system*
Scalability to change the current level of the specified system parameters*
Survivability to minimize the impact of limited duration disruption on value delivery*
Vulnerability to reduce the likelihood or magnitude of the disruption**
Sturdines
s value
to maintain value delivery despite changing needs or contexts*
Vulnerability to maintain a minimum acceptable level of value delivery during and after the
disruption**
* verbatim from (de Weck, et al., 2012, p.7)
** framed by (Richards, 2009, p.61)

38
While survival is widely accepted as unraveling into vulnerability, vulnerability, and
recovery, the literature on flexibility ranges from intrinsic design properties to tangible options
for stakeholder value. Informally, in the field of Marine Engineering, the two ilities are used
interchangeably to describe the ability to maintain the performance of a system; However, the
main distinguishing differences in applications come from the origin of the interference in the
system, and the identification of possible system attributes. Disruptions that require system
resilience are posed by deliberate threats to degrade system performance, whereas flexibility
disruptions are based on the competitive performance of the system itself or the capabilities that
stakeholders want. Persistence is most closely related to the short-duration flexibility sub-type,
due to the nature of real-time limited duration disruption.
4.2 Framework for Space Exploration Design
In early-stage design, the assessment criteria for determining the preferred solution can be
challenging to elaborate. Often, designers are faced with a large number of viable architectures
that meet key functional requirements. This study presents a framework for establishing metrics
that measure the value of system diseases, as a means to identify preferred solutions in the design
space. It is applied here, in the evaluation of power and energy systems to take into account the
multi-disciplinary aspects of the system system. It is hypothesized that, in complex system-of-
system designs, the lowest level of the system definition is the selection of design variables that
are combined to form the metrics used to measure ility. The framework shows that a set of
common architectural attributes can be linked in a way that aims to develop system metrics and
characterize ilities. The output of the P&E system framework focuses on the "Right Measure" of
the system, finding a balance between uncertainty, performance, cost, and complexity. The
framework for the exploration of the design space consists of the elements in Table 2.
39
Table 2. Framework for Establishing Ility Metrics
Step Action
1. Define the properties of the system that appear that are interesting.
2. Characterize the attributes of a system in terms of its physical, logical, and
operational architecture. Define the system boundaries and necessary interfaces in
the logical model of the system.
3. Assign a viable solution design trading space, which is determined by the low-level
system attributes of each option.
4. Identify a comprehensive set of potential disruptions that affect emerging system
properties. Maintain the Immediate External Disruption (IEP) perspective, as
proposed by Hein (2022), tracing the chain of effects caused by the broader
influence on the system system down to the disruption that occurs directly at the
boundaries of the subsystem.
5. Start connecting potential preparations in the design to a set of distractions to verify
the sturdiness of the potential design solution's space. Break down the preparation
into its basic attributes in the physical, logical, and operational view of the system.
6. For disturbances of interest, generate design metrics to measure the value of the
system under the influence of changes caused by a given disorder. Leverage the
physical, logical, and operational attributes of the system to identify independent and
dependent variables.
These steps are shown in Sections 5 and 6 to develop metrics to measure the flexibility of the

40
Navy's power and energy systems and how to balance performance with system affordability.
5Flexibility for Ship Design
Flexibility is ility that often comes up in discussions about complex system attributes and
requirements but lacks a clear and consistent definition. From the literature review in Part 2,
several authors have identified common characteristics of flexible systems in the context of
Naval Architecture and ship design, but at varying degrees of specificity. (Chin, Yau, Kok Wah,
& Khiang, 2013) discusses a comprehensive maritime system system, which attributes flexibility
to the degree of ease of making changes to maintain mission effectiveness in response to
external or internal disturbances. At the platform level, (Doerry & Koenig, 2017) has expanded
the definition of "ease" to include measures of speed, timeliness, and cost, and (Hein, 2022)
identifies that disruptions can be anticipated or unknown at the time of making the necessary
design decisions that determine the capabilities of the platform. (McCauley, Hannapel, Bassler,
& Koleser, 2016) identified mission systems as a driver of platform flexibility, which (Schank,
et al., 2016) relates to the ability to change the boundaries of a physical platform by providing
excess space and flexible infrastructure.

41
From the perspective of the commercial energy industry, the International Energy Agency
(IEA) defines the flexibility of a power system as "the ability to respond in a timely manner to
variations in electricity supply and demand" (Gutierrez Tavarez, 2019). This definition of
industrial flexibility can be tailored to naval power and energy system applications on board
and used to develop metrics for early-stage design evaluation.
5.1 Power and Energy System Flexibility
Flexibility is the ability of a system to accommodate changes in response to disruptions in
requirements. The usefulness in the application of flexibility depends on the boundaries of the
defined system and the difference between short-term and long-term impacts. Requirements,
such as Top-Level Requirements or system specifications, refer to the measurable needs of
stakeholders. Requirements can be organized into the physical, logical, and operational context
of the system to better understand the design drivers and determine possible design
characteristics.
For naval power and energy (P&E) systems, flexibility is measured within system
boundaries, in response to disruption from new loads and changes that require power (demand)
or changes to energy flow sources (supply). The following discussion, in Sections 5.1.1 to
5.1.3, defines power and energy systems in the construction of physical-logical-operational
capabilities introduced by (Brefort, et al., 2018). Together, these systems
the view connects "the right strength, the right location, the right time, and the right conditions" (Doerry, 2014).
5.1.1 Physical
The physical view is concerned with the spatial configuration of the system and the physical
attributes of each subsystem and component. A P&E system is a distributed system that covers
the entire ship and consists of many components that are usually listed on the Machine
42
Equipment List (MEL). In this view, a system can be described as a series of nodes that
represent each component or closed subsystem. Each node is assigned a location using a
coordinate system to establish integration in the entire ship architecture and to determine the
location of the nodes in relation to each other. The metrics used to measure the physical
requirements and characteristics of the system include a measure of distance and the physical
attributes of each component, including space, weight, power, and cooling (SWAP-C). The
following list of attributes, in the context of physical display, can be used as parameters and
variables to develop power and energy system metrics.
Power and Energy Systems - Physical Attributes
Place
Access, required transfer routes, and reservations
Distance between nodes
Gross number and percentage of boat compartments touched
Stacking length
Number of components by type
Direct Costs

43
Control system computing and processing equipment
Component level
oSpatial: area and volume
oHeavy
Weight of components
Weight per meter (for distribution components)
oPower level (supply and/or demand)
Installed power versus available power (by type)
oCooling level (supply and/or demand)
oEfficiency and disadvantages
oFuel consumption
oPower density
oSpecific power
System level (number of components by type)
oSpatial: area and volume
oHeavy
oPower level (supply and/or demand)
Installed power versus available power (by type)
oCooling level (supply and/or demand)
oEfficiency and disadvantages
oFuel consumption
oPower density
oSpecific power

44
Flexibility in physical display is driven by system configuration. The selection of
components consisting of power and energy systems and their integration in the ship's platform
determine the potential flexibility of the system. Component capacity is measured against the
system's requirements for supply and demand. Options for implementing flexibility in system
attributes include the provision of traditional Life Allowance margins on SWAP-C, the
installation of excess capacity (e.g., installed power plants) beyond the initial platform
requirements, and specifying system interface standards for future subsystem integration.
Spatially, the architecture of the P&E system must be arranged to align with the hull features
and electrical zones. Options for implementing physical-spatial flexibility include designing
reconfigurable spaces, providing access points and equipment, or reserving excess manageable
areas within a defined hull compartment. Modularity, a design feature that allows for the
swapping or plug-and-play capabilities of various system sub-modules within a specified
location and interface standard, is defined in physical display.
5.1.2 Logis
The logical view describes the functional characteristics of the system and the relationships
between the components of the system that enable the emerging capabilities. Power and energy
systems are multidisciplinary, with components connected across mechanical, electrical, thermal,
and signal domains. Figure 8 depicts the flow of electric power, thermal aids (water and
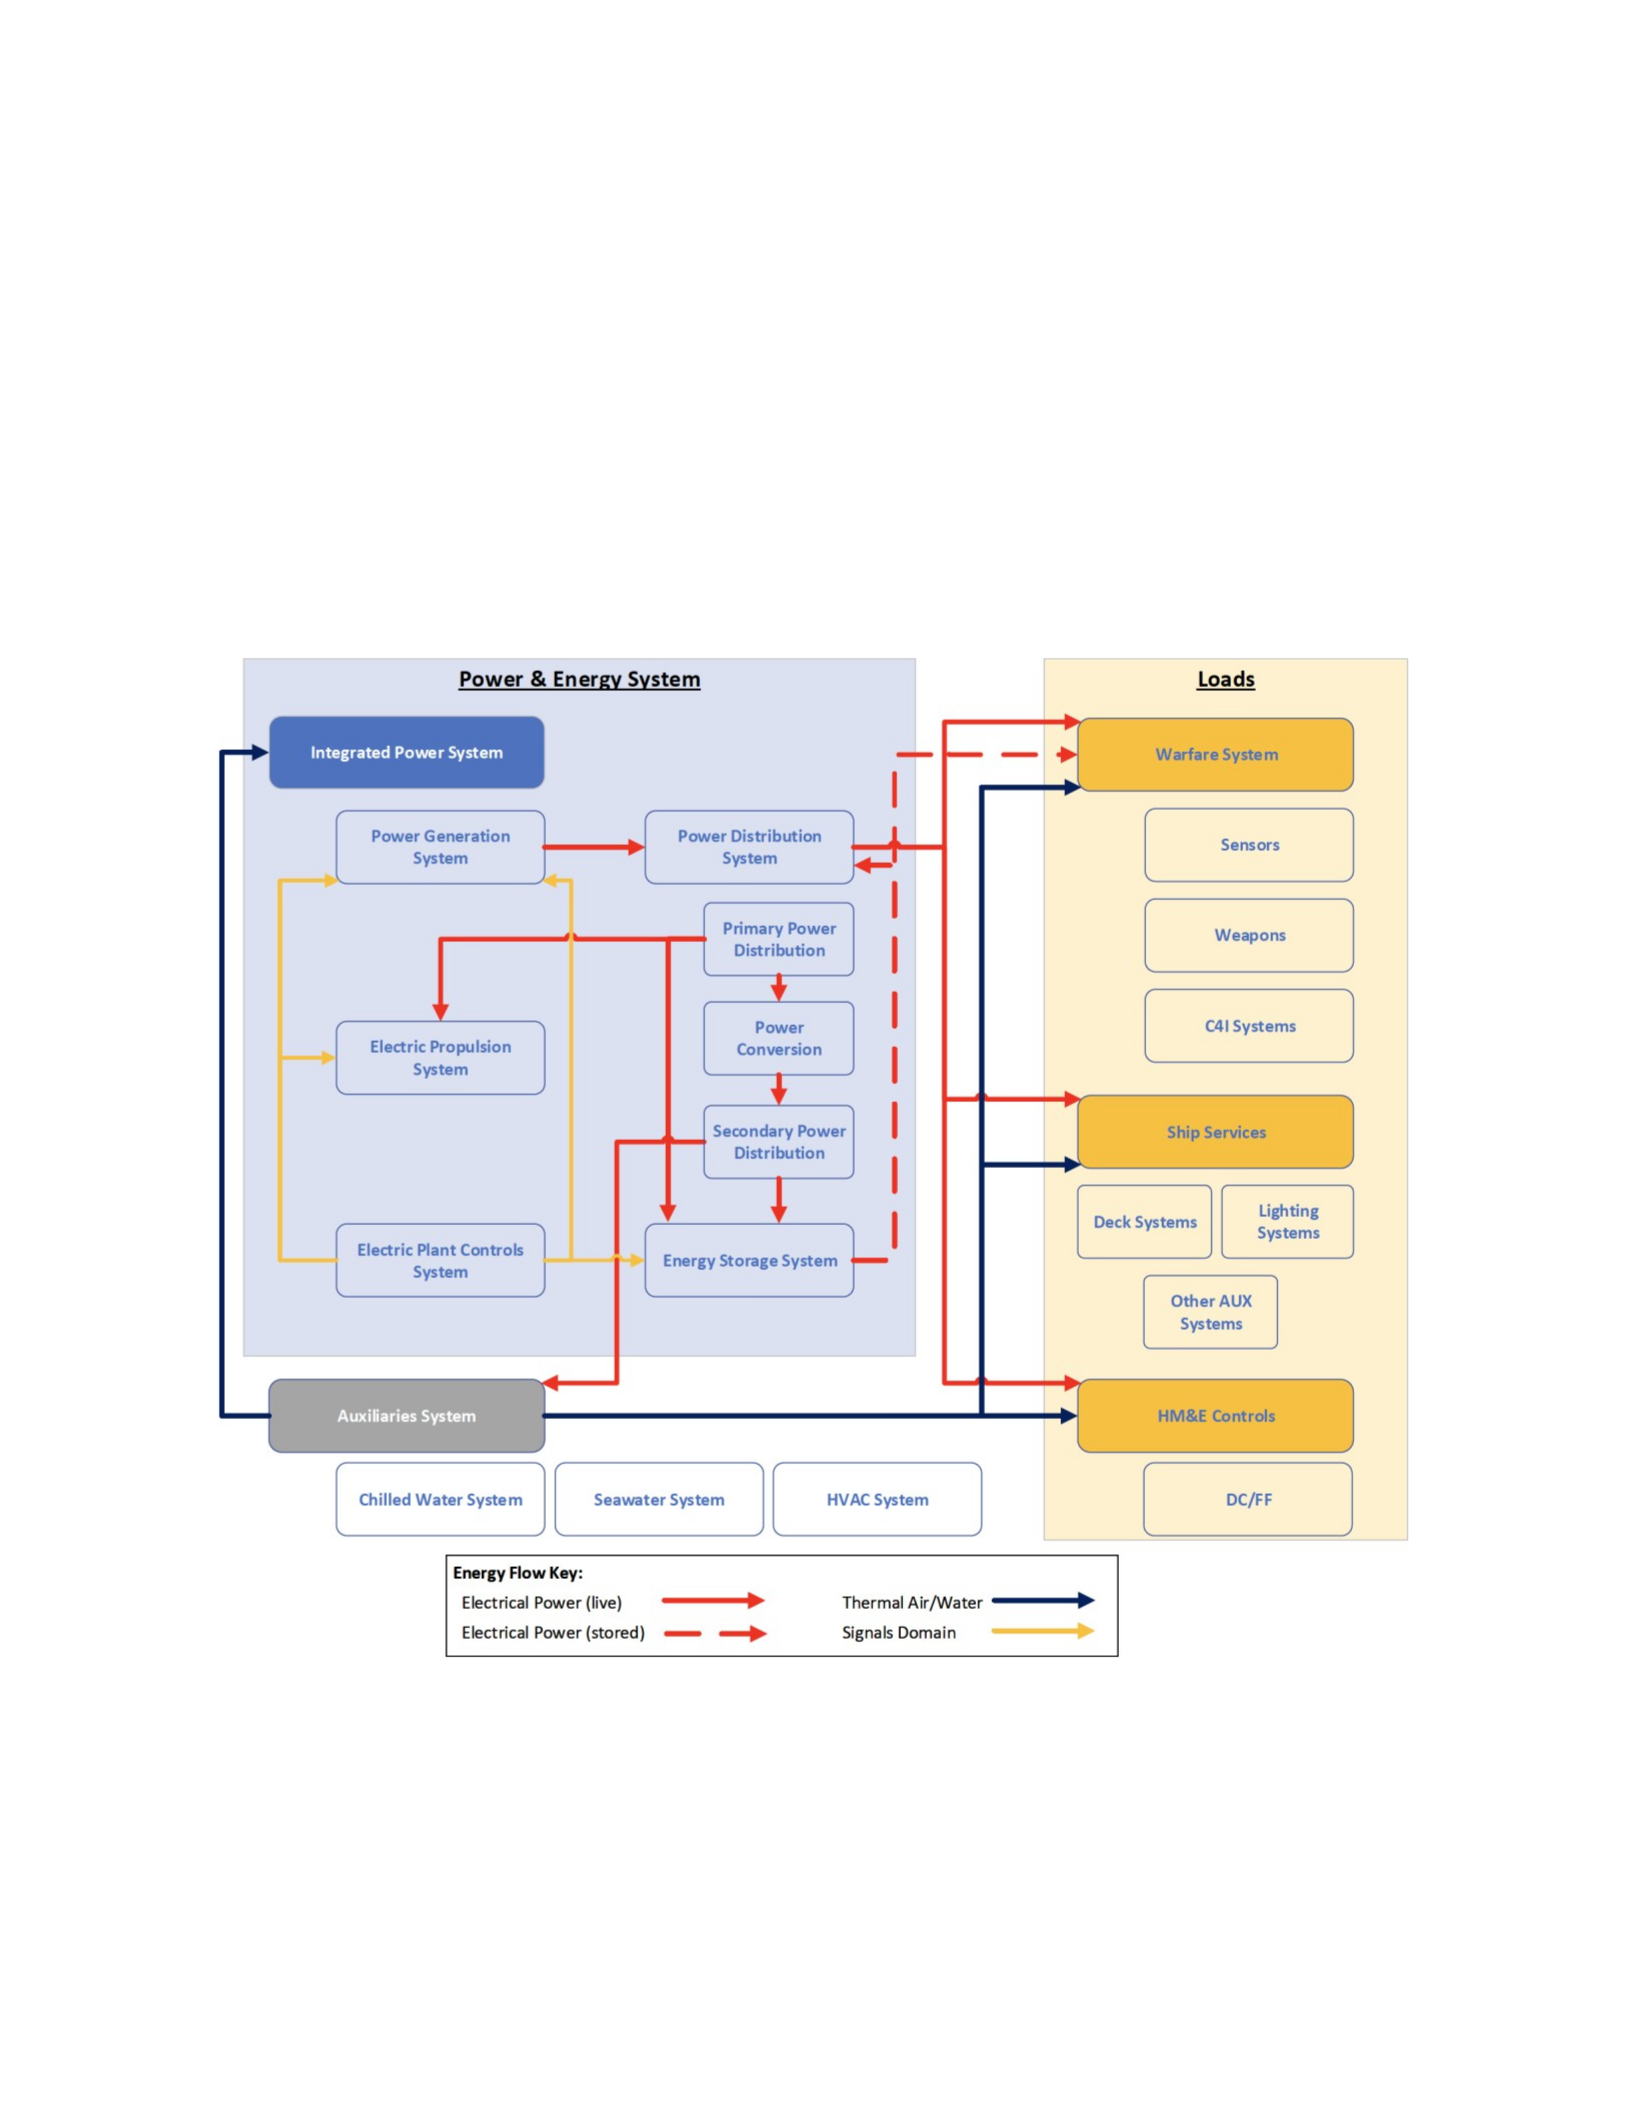
45
air), and data across the electrical, thermal, and signal domains for representative Integrated
Power System architectures. In the IPS configuration, as described in Section 1.1, the propulsion
module is considered in the power and energy system, represented as an external load. In logical
view, links are identified to connect individual subsystems or component nodes created in
physical view. Each relationship needs its direction, type, and magnitude to represent a flow in a
defined domain.
Figure 8: Logical Model of Power and Energy System for Integrated Power System (IPS) for
Combatants
46
The following list of "ility" specific attributes, in the context of a logical view, can be used
as parameters and variables to develop power and energy system metrics.
Power and Energy Systems - Logical Attributes
●Number of flow types
●Number of links on each node (total and per domain)
oSupply links
oRequest link
●Standard interfaces (types and quantities)
●Energy flow capacity
●Number of alternative paths for a given energy flow
oTime and cost required to switch between paths
●Mechanical Domain
oEquipment type: motor, gas turbine, diesel
●Electrical Domain
oEquipment type: battery, gas turbine, diesel, fuel cell
oDistribution type: frequency, voltage, current (combination)
●Domain Termal
oWater system type: cold water, fresh water, seawater
oAir system type: ambient, forced air, air-conditioned
●Signal Domain
oControl system type: localized, enclave, network
oControl system interface type

47
oControl system direction: two-way, one-way
Flexibility in a logical view focuses on the system's ability to provide the necessary
relationship between supply and demand elements in each functional domain when the system
becomes aware of future disruptions in requirements. Power and energy systems include a
network of distributed systems to allow flow within each domain. The functional flexibility of
these systems often centers on the conversion and distribution of flows and the types of
compatible supply and demand elements. To facilitate system measurement and design
decision-making, the SWAP Box method introduced by (McCauley, Hannapel, Bassler, &
Koleser, 2016) can be used to represent unknown future elements that require a variety of
potential P&E system services. The logical view also provides insight into the ability to
reconfigure the system in response to a realized glitch.
5.1.3 Operational
The operational view defines the temporal behavior of the system that is necessary to
complete a particular mission, including the sequencing of system functions. This view connects
the physical and logical aspects of a particular architecture to the performance of the system,
often referred to as the Performance Measure. Typical design requirements, as identified in
Section 1.2, specify the desired functional capabilities in a particular operating scenario.
Scenario timescales can range from instantaneous system responses to multi-year expenditures,
such as estimated maturity and technology integration. For power and energy systems, these
requirements can target the specific capabilities of components within each specified domain
(supply side) or come from higher-level platform performance requirements (demand side), such
as those related to the energy consumption of the platform. The following list of attributes, in the
context of an operational view, can be used as parameters and variables to develop power and

48
energy system metrics.
49
Power and Energy Systems – Operational Attributes
Operating duration
Opportunity cost
oUpfront fees
oReconfiguration fees
oAlternative investment costs
Classification of supply sources and demand loads
oVital vs non-vital
oMission important
Number of required operating (loading) modes
Scale each required mode of operation (loading)
Loading conditions:
oNumber and magnitude of Serviced load (power)
oAmount and magnitude of Loads served (thermal)
oShip Speed
oFlow rate
Component Life
Battery charge and discharge rate
Response time (e.g., breakers, signals, generator starts, backups, and parts)
Pulse loading
Mechanical Speed, rotations per minute (RPM)
Specific fuel consumption at loading speed and conditions
Dynamic simulation output

50
Operational flexibility is differentiated between requirements for instant response to real-
time changes in running conditions outside of design requirements, and system reconfiguration
in response to requirements changes that arise over large time scales (order of magnitude in
years). The various combinations of demand loads (combat systems, ship service, and
propulsion loads) that require service and energy flows in each domain determine operational
scenarios for power and energy systems. Examples of operational flexibility include the ability
to discharge power from one load category to serve another, the use of energy storage in
response to real-time operational changes or service disruptions, and the ability to combine
elements of future combat systems with unique load profiles, such as pulse loads.
5.2 Disruption to Flexibility
Disruptions in requirements beyond the initial system design criteria drive the need for
flexibility. For power and energy systems, the disturbances are traced from the broader system
context to the direct impact on the system boundary in a logical view, Figure
8. They are easily identified based on impacts associated with the source of energy flow
generation (Supply) and the required load (Demand). The method for localizing influence on
this system is based on the concept of Immediate External Interference (IEP), proposed by
(Hein,

51
2022). The process of identifying IEPs is essential for establishing the metrics necessary to
determine the value of a system in the context of any ility requirements.
Table 3 and Table 4 identify disruptions in P&E systems that require flexibility to maintain
the capabilities and value of the system. They are distinguished by the response time required to
change the system. Short-term disruptions are realized while the system is operating; they
needed a flexibility solution for the P&E system to maintain acceptable performance with
existing system components and configurations, including software and controls. The
identification of operational disruptions should be balanced with the range of required operating
conditions that the system will be designed to achieve, so that disruptions represent new
requirements or unforeseen criteria for maintaining desired operation. Long-term disruptions are
realized over a long period of time, often projected years before realization, and can be met with
planned system upgrades in the future.
The following set of impairments is considered against potential preparations in the
design that require flexibility in the appearance of physical, logical, or operational systems.
Further disruptions may apply to the evaluation of the P&E system in the context of other
illities but will require adjustment of the impact of the related system. The basis of operational
flexibility in power and energy systems is strongly correlated with disruptions for survival and
reliability, i.e. disruptions stemming from equipment failures and maintenance measures.
(Doerry & Amy, 2011) defines a design metric for related ility, quality of service (QoS), to
address unexpected service interruptions, which can lead to disruptions in operating
requirements and conditions. Each of the disorders below is not limited to the immediate
impacts and applicable design preparations listed but has the potential to produce cascading
effects that trigger additional flexibility-related impairments and other necessary ailments.
52
Table 3: Short-term (operational) disruptions beyond initial design requirements that require
Flexibility.
Gangguan Subtype System Design Preparation Example
Change of
propulsion load
from design to
new conditions
The demand for
propulsion loads varies
from design conditions
e.g. propellers,
shafts, gears, motors,
drive efficiency
Changes in how
ships plan to operate
in service (e.g. twin
shafts vs trails)
Physical: Built-in capacity
(power & cooling); Selection of
component types
operational: change the mode
of operation; discharge of
energy flows from other
requests
IPS Architecture:
Installation of power
plants and supply &
demand of propulsion to
maximize efficiency
across the desired modes
of operation
Load variation of
expected design
conditions:
Combat/mission
system elements
Physical: Built-in capacity
(power & cooling); Location of
distribution elements (including
zones)
Logic: the amount and type of
energy flow required
IPS architecture:
reduce propulsion
demand to increase
mission load
Primary/secondary/
combat system power
distribution architecture
Cable HTS
Capacity and
53
Change of
mission/combat/se
rvice load of the
ship from design
to new conditions
Additional elements
Elements of ship
service
operational: change the mode
of operation; discharge of
energy flows from other
requests
control of power
electronics, load
centers, SWBD
Offboard Vehicle
Hosting & Service
(Energy and Control)
Variation of power
quality anomalies and
differences from
expected design
conditions:
Frequency
voltage
current
physical: the size and location of
distribution and conversion
elements; Use of special equipment
Logical: number and type of
distribution and conversion
elements
Power Electronic
Building Block
(PEBB)
Modular power
converter
The type of cooling of
the demand element
differs from the design
conditions
Physical: cooling system
capacity, configuration, and
routing
Logic: number and type of
cooling source
Operational: Determine the
loading condition, change the
operation mode
Chilled/fresh/marine
water and HVAC
system design: capacity,
redundancy, location,
loading conditions
Physical: additional system capacity
54
Operating
environment
Temperature changes:
Atmosphere
Cooling water source
air internal
compartment
Logic: number and types of
assistants/alternative
recommendations
operational: change the mode
of operation; discharge of
energy flows from other
demands; Change in flow rate
Specified operating
modes for load release
Operable aids
(FW/SW/CW)
Threats/signatures
physical: special equipment
required; location of the specified
element; Number of elements
needed per energy flow
Logic: Operational System
Management Control: Change
operating mode
Design for signature
mitigation in specific
operating modes
Signature Augmentation
Fuel type change
physical: selection of power
generation equipment; Types of fuel
input systems
Operational: Efficiency
Reduced fuel availability Operational: Change the mode of
operation
55
Unique load types
Pulse load, variation of
design expectations
Physical: including specialized
energy conversion, distribution, and
storage equipment; location of
distribution and conversion
equipment; Size of supply and
distribution elements to maintain
system inertia
Logical: management of
control systems; Number and
types of distribution and
conversion elements
operational: sequencing and logic
of load conditions and operating
modes; discharge of energy flows
from other requests
Integrated energy
storage - types and
capacities
battery,
flywheel,
capacitor
IPS architecture -
dynamic loading
capability
High power short-
duration load, variation
of design
Hope
Ramp-rate, a variation of
design expectations
56
Table 4: Long-term disruptions (realized in future maintenance periods) beyond the initial design requirements
that require Flexibility.
Gangguan Subtype System Design Preparation Example
Changes in power plant
components
physical: weight and adjustable
space margin; access/deletion
routes; Distribution system size
Logical: compatibility of energy
flows (voltage, frequency,
current, auxiliary); Modified
control system logic
operational: change the mode of
operation; Efficiency changes
generator swap
(GTG/DG)
Adding additional
generators to existing
plants
Modified distribution
system
physical: weight and adjustable
space margin; Pre-planned Setup
and Routing
Logical: modified control system
logic; Number and type of electrical
support connections and additions
operational: change of mode of
operation; Efficiency changes
replace conventional
with high-temperature
superconducting cables,
or MVDC cables (cable
bundling, number)
Modular Power Node
defined interfaces
(spatial and physical)
accessible cable trays,
cable corridors, cable
57
P&E system
configuration
changes
breaks
Improved power
electronics and
switchboards
physical: SWAP-C margin;
pre-planned arrangements and
routing; Hazard Mitigation
logical: modified controls;
Changes in the quality of
energy flow
Operational: Operation mode
change, efficiency change
PEBB
Modular SWBD, load
center cabinet, electric
bus
New/additional
secondary distribution
loops (goal-driven)
physical: weight and adjustable
space margin; Pre-planned Setup
and Routing
Logical: modified control system
logic; Number and type of electrical
support connections and additions
operational: change of mode of
operation; Efficiency changes
Distribution of
special combat
systems
Defined interface,
specified power
quality
accessible cable trays,
cable corridors, cable
breaks
Physical: rating of the
propulsion system; adjustable
higher or more
efficient: turbine
58
Change the elements of
the propulsion system
weight and space margin
Logic: compatibility of the
shafting system; Number and
types of additional supporting
connections
(mechanical), electric
motor (IPS)
change the type of
motor
(AIM/PMM/HTS/Po
dded)
Switch to motor drive
operational: change the
operation profile; efficiency
changes; discharge of energy
flows from other requests
Change the topology of
the propulsion system
physical: SWAP-C margin;
Pre-planned arrangements and
routing subsystem capacity
(generation, distribution,
conversion, increment)
Logic: the amount and type of
energy flow required; Modified
Controls
Operational: Change of operation
mode
Mechanical to hybrid
conversion
physical: SWAP-C margin; Expand energy
59
Change the energy
storage system
pre-planned arrangements and
routing; Hazard Mitigation
logical: energy flows of number
and type; additional interfaces;
Modified Controls
operational: change of mode of
operation; Efficiency changes
capacity (additional
point-of-use system
capacity or integrated
energy storage)
Changes in technology
or combinations of
battery types, rotating
engines, etc.
Required - Fire
Fighting and Safety
System
Changes to
payload:
New load types (pulse
load, ramp rate, etc.).
physical: SWAP-C margin; the
inclusion of specialized
equipment; Pre-planned Setup
and Routing
logical: modified controls;
Number and type of energy flow
connections
Operational: Change of operation
mode
Interface Control
Document for planned
future upgrades
Integrated energy storage
Dynamic loading
capability
Physical: Generation,
IPS architecture -
reduces propulsion
60
mission/combat
systems, ship
service, support
Increased demand:
vital/nonvital
Load Case Conditions
Distribution, Conversion,
additional subsystem capacity
operational: discharge from
other energy streams; Change of
operation mode
demand to increase
mission load
Interface Control
Documentation for
planned future updates
New responsiveness
(agility) requirements
physical: the inclusion of
special equipment; Margin
SWAP-C
logical: the amount and type of
energy flow; Modified Controls
Operational: Change of operation
mode
Inclusion of energy
storage and power
electronics
Request location change
physical: weight and adjustable
space margin; Pre-planned
distribution and conversion
capacity, setup and routing
Interface Control
Document for planned
future systems
Flexible infrastructure
Secondary impacts
realized in the
physical: weight and adjustable
space margin; Additional system
capacity
Ability to run multiple
water-cooled systems to
a specific load

61
ancillary system
operational: discharge from
other energy streams; Flow Rate
Thermal Battery
Additional Air
Conditioning Factory
Modified damage
control and fire
extinguishing
requirements (response
to other configuration
changes)
physical: adjustable space; Pre-
planned Setup and Routing
Logical: modified control
system; Defined interface
Operational: Change of operation
mode
Reconfigurable Zones
Planned operation of
piping, standard piping
joints or valves
HVAC
intersection and
connection; Fan
room
arrangement
Personnel upgrades
physical: HVAC and electrical
capacity; Request location
Logic: electrical and
auxiliary connections
Changes in
command
Introduction to Artificial
Intelligence (AI)
physical: processing capacity;
inclusion of special hardware
(sensors-processors-actuators);
logical: HW/SW data
P&E system
designated: Modular
electronic enclosure
Platform/System
Network Configuration
Requirements for
autonomous operation;
Personnel reduction
62
and control connection; Control Logic
operational: change of mode of
operation; internal/external
communication; Maintenance of
the P&E system;
Signature/Security
distributed and
multifunctional
control stations
Off-platform
communication and
control
HM&E Control
Power Plant Control/IPS
Operating
Environmen
t
Arctic Operations
physical: HVAC and electrical
capacity; Request location
Logic: electrical and
auxiliary connections
Loading plugins (hot/de-
es)
Environmental
regulations
physical: selection of power
generation equipment; energy
storage size; Fuel type
operational: change of mode of
operation; Efficiency changes

63
6Metrics for Flexibility
Design metrics are quantitative or qualitative measures of system characterization and
measured value. In the early stages of design, metrics are formulated to assess the system's
ability to achieve design requirements and other desired capabilities, including ilities. When
evaluating a large multi-attribute trading space of a potential system architecture, alternative
design instead uses two or more sets of metrics to understand the design trade-offs and
determine the preferred or non-dominated design. A typical trading space exploration will
evaluate primary and secondary performance measures against cost requirements to uncover
system configuration trends within an open design trading space.
System attributes in a physical, logical, and operational view, as identified in Sections 5.1.1
to 5.1.3 for power and energy systems, serve as a foundational element for capability metrics. For
things like flexibility, any measure of performance can be traced to the physical attributes of the
elements that make up the system; However, the logical and operational nature of these elements in a
wider system configuration is necessary to achieve the desired emergent capability. Flexibility, due to
the ability to make changes in a system in response to interference, requires initial consideration of
how the chosen architecture will respond within each design domain.
For U.S. Navy ship design, the standard measure of flexibility is the Service Life Allowance
(SLA) requirement, which equates each ship's intended year in service with a measure of future
growth and fatigue capacity based on historical trends such as weight growth and increased
electrical load demand over time. The Navy's design authority, the Naval Marine Systems
Command (NAVSEA), breaks down SLAs into space, weight, power, and cooling-specific
design domains (SWAP-C). This allowance is used to inform the design of power and energy
systems and auxiliary systems, measure the shape of the hull, and design the hull structure. For
64
power and energy systems, SLAs represent flexibility based on gross capacity, but do not
address the necessary decomposition to the subsystem level such as the necessary preparation in
power distribution and energy storage modules to ensure the intended future capabilities can be
achieved. Table 5 shows the Service Life Requirements defined in the NAVSA Naval Combat
Design
Specifications' (2014) in each of the SWAP-C criteria, for vessels with an expected service life.
Table 5: Required Life Allowance for 20 and 30 years
Life Allowance 20 Years 30 Years
Space 0% 5%*
Weight & KG 10% & 0.3
million
10% & 0.4
million*
Power** 15%* 20%
Cooling 15%* 20%
*Notional value, not specified in NCDS
**Values based on IPS representative traditional separate vessel service manpower system

65
The following sections identify metrics for evaluating the flexibility of power and energy
systems in early-stage design space exploration activities, such as concept formulation,
preliminary design, alternative analysis, or requirements evaluation and development. The
distinguishing factor of early-stage design is the relatively low amount of design-specific
information available to determine the system architecture. Designers and decision-makers will
typically start with a list of initial machine tools of components that drive acquisition costs and
determine gross system capacity, such as prime movers, generators, power converters, and
transformers. The size and quantity of these components are balanced with an estimate of the
first-order load demand based on historical regression or ratio, the known demand from the
required mission equipment, and the initial system layout in the conceptual ship stacking setup.
The following process traces the disruptions identified in Section 5.2 to three categories of
system flexibility requirements: power capacity, distributable power, and energy storage.
Metrics to characterize capabilities in each category are proposed using physical-logical-
operational system attributes. This process can be used to develop ility metrics to incorporate in
early-stage design tools, such as the Leading Edge Architecture for Prototyping Systems
(LEAPS) suite of product model tools, including Smart Ship System Design (S3D) for energy
flow analysis.
6.1 Power Capacity
Flexible power capacity depends on the physical attributes of the power plant subsystem and
the design rating of its components. In an operational perspective, flexible power capacity
depends on the specified supply operating conditions of the power generation subsystem and the
demand from the ship's mission system and service elements. While the overall power and
energy system can be measured based on defined Life Allowance requirements, the definition of

66
operating conditions provides a realistic measure of the system's ability to accommodate
potential future loads. For IPS systems, power flexibility is determined by the size criteria of the
ship's power plant subsystem, including requirements-driven loading conditions. Sufficient
power generation is required to power the electric propulsion motors, provide ship service
power, and operate the ship's mission systems. Requirements-driven loading conditions
determine the combination of ship speed and electrical load of the mission system that requires
simultaneous power supply. Typically, the power plant's size requirements will determine the
propulsion load required to ensure sustained speed, as this is the order of magnitude load highest
on board. The corresponding electrical load of the mission system depends on the purpose of use
of the platform, which may require the vessel to operate the most stressful mission load at
sustained speed or a representative average of the daily load experienced during mission
operations.
Flexible Power Capacity (FPC) metric. Equation (1) defines the flexibility power
capacity (FPC) as the sum of the total available distributable power (PDST ), based on the
capacity of the generating and distribution subsystems; minus the sum of all required loads
(LREQ) in the system size criteria used for the calculation, such as the 24-hour average load or
the maximum margin electrical load; divided by the total installed power (Ptot). Distributable
power including energy

67
generated on board the ship available for the ship's mission and service systems, whereas
depending on the architectural topology, the total installed power includes all the energy
generated. For example, in an IPS architecture, the distributable power may be equal to the total
installed power, but the mechanical architecture will have a separate ship service power plant
and a dedicated propulsion diesel or gas turbine directly connected to the shaft line. FPC
metrics provide a measure of relative flexibility for alternative architectures that meet similar
mission requirements and should not be used to compare platforms with drastically different
initial load requirements. For these types of high-level material solution considerations, the total
size of excess capacity in megawatts is more appropriate. Section 6.1.1 outlines the differences
in applying metric (1) to different power and energy system architectures.
FPC = PDST− LREQUEST
Ptot
(1)
Metrics of Renewable Power Flexibility (DPF). The second metric for flexible power
capacity utilization in IPS architectures, where the total power generated is required to serve
propulsion as well as mission and ship service loads, is the flexibility of dischargeable power
(DPF), equation (2). Where FPC Metrics consider the physical architectural elements of a
system under specified loading conditions, Dischargeable Power Metrics consider the
operational architectural capabilities for the system topology applicable across a wide range of
operational loading conditions, determined by a combination of load requirements.
Dischargeable Power is the ability of IPS systems to prioritize the load receiving power,
effectively discharging power from one load category to serve another. Since the largest
magnitude load by category is the propulsion load at continuous velocity (Lps), the available
68
dischargeable power load (Lavail) is the propulsion load used to measure the propulsion
subsystem (LpREQ) minus the propulsion load required to make the minimum acceptable
mission speed (Lpmin). The DPF is then the minimum of the new load request above the initial
design requirement (Ladd) and the available dischargeable power load, divided by the new load
request. Case 2 will discuss the sensitivity of IPS power flexibility to the selected sizing,
propulsion, and mission load criteria.
The mana lavel = lprac −
lpmin.
DPF = min
(Ladd, Lavail)
Ladd
(2)
A phenomenon observed when using this metric to compare the power and energy systems
integrated in a ship concept with a wide range of hull efficiencies is that a less efficient hull
requires a greater installed power capacity to achieve the same top-end speed, thus providing a
greater dischargeable power load available when the propulsion requirement is reduced to the
minimum acceptable speed. However, these perceived benefits sometimes only lead to the
selection of a system within the trading space when balanced with other attributes, such as cost.
The right size of the power plant subsystem to align with the desired mode of operation leads to
the preferred architecture.
Propulsion Shaft Horsepower
70000
60000
50000
40000
30000
20000
10000
0
69
6.1.1 Case 1: Flexible Power Capacity Metrics
The following example shows the application of the Flexible Power Capacity metric,
Equation (1), for three different power and energy system architectures: Integrated Power
Systems, Hybrid power systems, and mechanical propulsion systems with separate ship service
power plants. In each architecture, sensitivity to specific load conditions is demonstrated by
varying the load criteria for ship service and mission elements between the case of a 24-hour
average electrical load and the propulsion load between sustained speed and economical transit
(shipping) conditions. In addition, each demand load is evaluated on the initial shipment and
end-of-life conditions to indicate an increase in demand over time.
For the basis of this analysis, the notional ship concept is utilized from the NAVSEA
Design Data Sheet (DDS 200-2) for 'Calculation of Annual Energy Use and Cost of Surface
Ships' (2012). The concept has a design life of 20 years, requiring a 15% power SLA. Table 6
shows the electrical load for each operating condition of the design, including 50% of the SLA.
Economical transit is performed at 16 knots, a surge to the theater requires 30 knots of
propulsion power, and the ongoing mission propulsion load is based on the velocity-time profile
specified in DDS 200-2. The propulsion velocity power curve for the required shaft horsepower
(SHP) per node is shown in Figure 9.
Table 6: Electrical Load Conditions at Various Temperatures and Operational Scenarios
(NAVSEA, 2012)
Temperature
(°F)
In the harbor -
Beach
Power (kW)
Ongoing - Economical
Transit (kW)
Ongoing - Surge to
Theatre (kW)
Ongoing -
Mission
(kW)
70000
60000
50000
40000
30000
20000
10000
0
0 5 10 15 20 25 30 35
Speed (kt)
70
10 1,000 3,000 3,000 4,800
59 500 1,800 1,800 3,200
100 900 2,400 2,400 4,000
Propulsion
Load
- 7,100 46,800 7,208
Figure 9: Propulsion Velocity-Power Curve (NAVSEA, 2012)
SHP (kW)

71
The three representative vessels were built using the same hull shape, mission system load,
and propulsion requirements, but with three different P&E system topologies: IPS, Hybrid, and
Mechanical. The DDS 200-2 representative ship concept is utilized for the Integrated Power
System, which consists of three Large Gas Turbine Generators (LTG), two Small Gas Turbine
Generators (STG), and two electric Propulsion Motor Modules (PMM). On the basis of this
comparison, alternative hybrid and mechanical architectures are created to provide comparable
power to both propulsion and mission loads, as shown in Table 7. In the IPS concept, PMM is
sized to achieve a design sustained speed of 30 knots at eighty percent of the maximum
continuous rating (MCR). The power generation subsystem, consisting of LTG and STG, is
sized to provide sufficient power for sustained speed conditions plus mission load at end of life
(EOSL), taking into account motor efficiency and power transmission losses. For the hybrid
concept, the propulsion subsystem consists of a PMM, sized to achieve an economical transit
speed of 16 knots, plus two propulsion gas turbines (PGTs) coupled directly one to each shaft in
an 'OR' configuration, so that the PMM and PGT do not combine to achieve a sustained speed,
and the required propulsion demand is supplied by one or the other. Hybrid power generation
subsystems are sized to provide full power to PMM and mission loads in EOSL. Finally, the
mechanical concept propulsion subsystem consists of four PGTs, two per shaft, and a power
generation subsystem sized to provide the mission load in the EOSL with one offline generator
for redundancy, referred to as the requirement (N-1). This requirement (N-1) does not apply to
IPS or hybrid architectures because the amount of installed distributable power capacity is
greater which allows the system to discharge the propulsion load to compensate for the generator
victim.
Table 7: List of Main Machine Tools
72
IP Hybrid (or) Mechanic
Number of
Units
Total kW Number of
Units
Total kW Number of
Units
Total kW
Large Turbines
Generator Set
(LTG)
3 72,000 0 - 0 -
Small Turbine
Generator Set
(STG)
2 6,000 5 15,000 3 9,000
Propulsion Motor
Module) PMM
2 60,000 2 8,000 0 -
Gas Propulsion
Turbin (PGT)
0 - 2 60,000 4 76,000
Built-in Power
Driving
Conditions
Generation
Continuous
Speed Propulsion
(30kt)+
EOSL mission
Propulsi Listrik Maks
(16kt) + misi EOSL
Misi EOSL (N-1)
Power plant
Needed
- 67,370 - 12,938 - 5,136
Total Installed
Power
5 78,000 7 75,000 7 85,000
73
The case of IPS architecture. In the IPS architecture, it is assumed that the full amount
of power generated can be distributed throughout the ship for the ship's propulsion or mission
load; thus, the Power Distributable (PDST ) is equal to (Ptot) at 78 MW. In reality, there may
be a limit on the amount of power that can be distributed on a single bus, limiting the power
available for non-propulsion loads based on a particular distribution architecture. The required
load (LREQ) depends on the specific combination of propulsion and mission load demands, and
the amount of service life consumed.
Table 8 specifies the Flexible Power Capacity for IPS architectures at sustained speeds
while operating in two different modes: mission in progress at 10° Fahrenheit, requiring
maximum margin electrical load, and ongoing economical at 10° Fahrenheit, requiring an
average electrical load of twenty hours. Each combination of loads will develop over the life of
the vessel as SLA is consumed and a reduction in the efficiency of propulsion of the fact of life
is realized. Required "on-delivery" loads include required propulsion shaft horsepower with a
PMM efficiency of 94% at sustained speed and declared mission loads without SLA. The "at the
end of life" load applies an additional 25% growth factor for SHP propulsion for hull fouling and
plant degradation and a 15% growth factor for mission load for SLA consumed. Table 9
provides the calculation of the Flexible Power Capacity for the same load condition at cruising
speed, where the PMM efficiency is 91%.
Table 8: IPS at sustained speed
IPS: Continuous Speed
Max Margin Load Max Margin Load 24 HR AVG di 24 AVG HR on
74
on Delivery (no
SLA)
on EOSL (with
SLA)
Shipping (without
SLA)
EOSL (with
SLA)
PDST (kW) 78,000 78,000 78,000 78,000
LREQ (kW) 54,253 67,370 52,578 65,444
Ptot (kW) 78,000 78,000 78,000 78,000
FPC 0.30 0.14 0.33 0.16
Table 9: IPS at Roaming Speed
IPS: Cruising Speed
Max Margin Load
on Delivery (no
SLA)
Max Margin Load
on EOSL (with
SLA)
24 HR AVG di
Shipping (without
SLA)
24 AVG HR on
EOSL (with
SLA)
PDST (kW) 78,000 78,000 78,000 78,000
LREQ (kW) 12,268 14,889 10,593 12,963
Ptot (kW) 78,000 78,000 78,000 78,000
FPC 0.84 0.81 0.86 0.83
75
The case of hybrid architecture. For hybrid architectures, where electrical propulsion
PMM is required to cover a smaller portion of the propulsion speed-power curve than IPS,
distributable power (PDST) is significantly less, at 15 MW. In this configuration, the propulsion
power at the upper end of the speed-power curve is provided by a special PGT on each shaft,
which is accounted for in the 75 MW Ptot. In operating conditions with high speed
requirements, PGT is online to provide a propulsion load, and LREQ only reflects the ship's
mission load. In conditions with speeds of up to 16 knots, the LREQ includes power for the
electric propulsion PMM in addition to the ship's mission load. Table 10 and Table 11 show the
difference between the loading conditions that require PGT and PMM propulsion services. In
each example, the LREQ is calculated at the maximum average load and twenty-four hours at
the time of delivery and at the end of the service life, as evaluated in the case of IPS. A PMM
efficiency factor of 94% is applied to the propulsion load in all cruising conditions (16 knots),
and a 25% hull fouling and factory degradation factor is applied to the end-of-life evaluation.
Table 10: Hybrid with Continuous Speed (PGT) Required
Hybrid: Continuous Speed (PGT)
Max Margin Load
on Delivery (no
SLA)
Max Margin Load
on EOSL (with
SLA)
24 HR AVG di
Shipping (without
SLA)
24 AVG HR on
EOSL (with
SLA)
PDST (kW) 15,000 15,000 15,000 15,000
LREQ (kW) 4,466 5,136 2,791 3,210
Ptot (kW) 75,000 75,000 75,000 75,000
FPC 0.14 0.13 0.16 0.16
76
Table 11: Hybrid with Cruise Speed (PMM) Required
Hybrid: Cruise Speed (PMM)
Max Margin Load
on Delivery (no
SLA)
Max Margin Load
on EOSL (with
SLA)
24 HR AVG di
Shipping (without
SLA)
24 AVG HR on
EOSL (with
SLA)
PDST (kW) 15,000 15,000 15,000 15,000
LREQ (kW) 12,019 14,577 10,344 12,651
Ptot (kW) 75,000 75,000 75,000 75,000
FPC 0.04 0.01 0.06 0.03
Mechanical architecture case. In the case of mechanical architectures, electrical power
distribution capacity (PDST ) is not required for any part of the propulsion load and, therefore, is
measured only on the basis of the ship's service and mission load. Propulsion demand, an order
of magnitude greater than the maximum margin electrical load, is served by a dedicated PGT
and is included in the total installed power (Ptot). The required load (LREQ) is calculated at the
maximum margin load and averages twenty-four hours at the time of delivery and at the end of
the service life, as evaluated in the case of IPS and hybrids. Mechanical power flexibility, Table
12, calculated based on the same loading requirements as the continuous velocity hybrid casing,
using PGT propulsion power.

77
Table 12: Mechanical (depending on non-propulsion)
Mechanical: Independent of Propulsion
Max Margin Load
on Delivery (no
SLA)
Max Margin Load
on EOSL (with
SLA)
24 HR AVG di
Shipping (without
SLA)
24 AVG HR on
EOSL (with
SLA)
PDST (kW) 6,000 6,000 6,000 6,000
LREQ (kW) 4,466 5,136 2,791 3,210
Ptot (kW) 85,000 85,000 85,000 85,000
FPC 0.02 0.01 0.04 0.03
Discussion. When establishing flexible power capacity requirements, the selection of
determining loading conditions should be based on the intended use of the platform and
CONOPS. The above case comparison provides the requirements owner with additional context
into the differences between the resulting architectures that will be driven by a specific set of
requirements for the designer to choose from. Figure 10 describes the flexible power capacity for
each IPS, hybrid, and mechanical architecture considered across a wide range of potential
loading requirements. Each of the eight loading conditions is plotted for IPS and hybrid
architectures, along with four mechanical load cases. Flexibility metrics are plotted against the
normalized power balance and the power available to serve needs due to significant capacity
differences for integrated versus separate power systems. This normalization indicates the
amount of power required for each individual load case versus the capacity of the physical
architecture installed.
Flexible Power Capacity
1.00
0.90
0.80 IP
0.70 Hybrid
0.60 Mechanic
0.50
0.40
0.30
0.20
0.10
-
FPC
78
Figure 10: Flexible Power Capacity (FPC) metrics for IPS, Hybrid, and Mechanical instances
versus normalized power capacity, the required load case over distributable power
0.50
0.40
0.30
0.20
0.10
-
0.000.100.200.300.40 0.50
LREQ/PDST
0.600.700.800.901.00

79
The IPS example architecture has an installed capacity beyond the minimum requirements
for the end life based on the selected combination of LTG and STG. The plant lineup identified
in DDS 200-2 (NAVSEA, 2012) targets improved energy efficiency at each operating condition,
which requires a mix of low- and high-power turbines aligned with the required load
combinations. This configuration provides flexible power capacity in every evaluation condition,
including the most stressful cases: continuous speed plus maximum margin electrical load with
full SLA consumption. IPS examples have five times the amount of power that can be distributed
as a hybrid example and thirteen times the number of mechanical examples. When evaluated for
Flexible Power Capacity, including consideration of total installed power and propulsion plus
vessel service load in each condition, the IPS example scored one and a half times greater than
the average hybrid PGT propulsion FPC value across four loading conditions, and eleven times
greater than the mechanical architecture FPC value on average.
Interestingly, Case's results determined that the flexibility of hybrid architecture FPC is
higher at high speeds, while the flexibility of IPS architecture FPC is higher at low speeds. In an
'Or' condition with online PMM (up to 8 MW), the flexibility measure of the hybrid architecture
is significantly reduced from the flexible power capacity when using PGT, as electric propulsion
consumes more than half of the power available for distribution. However, it should be noted
that there may be limitations in the minimum operating speed for scenarios that can take
advantage of the flexible power capacity of PGT-specific operating conditions based on the
minimum RPM of the propulsion gas turbine and the shaft propeller design.
The mechanical case requires the most installed power of the three architectures, as the load
required for the mission and propulsion is isolated to a dedicated power supply, resulting in the
lowest amount of distributable power. In addition, although the mechanical concept requires the

80
installation of redundant/backup ship service power plants to meet the requirements (N-1), the
third STG does not contribute to distributable power.
6.1.2 Case 2: IPS Dischargeable Power Flexibility Metric
This case uses the notional IPS vessel concept from DDS 200-2 (NAVSEA, 2012), as
described in Case 1, to demonstrate the metric of dischargeable power flexibility. Two variants
of the IPS architecture, with 30-knot and 27-knot sustained velocity (LpREQ) requirements, are
compared to isolate the impacts associated with specific architectural sizing criteria for the
required propulsion load. The debitable power metric for each variant is evaluated for a 1-knot
and 5-knot speed reduction in the minimum required propulsion load (Lpmin), both at the initial
and end-of-life delivery conditions. Three new sets of load demands on top of the initial design
requirements (Ladd) were then used to represent various future mission system requirements.
Table 13 shows the dismissable power flexibility (DPF) for a 30-knot IPS architecture,
given the 1-knot speed reduction for the minimum acceptable propulsion load at the time of
transmission and EOSL conditions. Table 14 calculates the DPF metrics for the same architecture
but
81
with a speed reduction of 5 knots for the minimum acceptable propulsion load. An additional
25% propulsion factor applied to EOSL conditions reduces the debitable power load (Lavail) by
11 MW in the case of a 1-know reduction and 7 MW in the case of a 5-knot reduction. This
results in lower DPF values when assessed against a 15 MW load for a 1-knot reduction case and
a 30 MW load for a 1-knot and 5-knot reduction case. In all acceptable minimum propulsion
conditions, the 30-knot IPS architecture easily accommodates the additional load case of 2 MW.
The 5-knot speed reduction significantly increases the availability of the dischargeable power
load, a 94% increase in delivery conditions, and a 340% increase in EOSL conditions.
Table 13: IPS 30 knot Dischargeable Power – 1 knot Reduction
Propulsion
Conditions
Kw Propulsion
Conditions
Kw
LpREQ 30kt, 100% MCR 62,234 LpREQ 30kt, 100% MCR 62,234
Lpmin 29kt, Delivery 45,014 Lpmin 29kt, EOSL 56,268
Availabili
ty
17,220 Availabili
ty
5,966
Ladd (kW) DPF Ladd (kW) DPF
Load 1 2,000 1.00 Load 1 2,000 1.00
Load 2 15,000 1.00 Load 2 15,000 0.40
Load 3 30,000 0.57 Load 3 30,000 0.20
Table 14: IPS 30 knot Dischargeable Power – 5 knots reduction
82
Propulsion
Conditions
Kw Propulsion
Conditions
Kw
LpREQ 30kt, 100% MCR 62,234 LpREQ 30kt, 100% MCR 62,234
Lpmin 25kt, Delivery 28,812 Lpmin 25kt, EOSL 36,015
Availabili
ty
33,422 Availabili
ty
26,219
Ladd (kW) DPF Ladd (kW) DPF
Load 1 2,000 1.00 Load 1 2,000 1.00
Load 2 15,000 1.00 Load 2 15,000 1.00
Load 3 30,000 1.00 Load 3 30,000 0.87
The 27-knot sustained speed variant of the notional IPS architecture assumes the same
velocity-power curve performance of the hull, but the reduced top-end speed requires less total
installed power. Table 15 shows the flexibility of dissipable power for a 27-knot IPS
architecture, given the 1-knot speed reduction for the minimum acceptable propulsion load at the
time of delivery and EOSL conditions. Table 16 calculates the discharge power metric for the
same architecture but with a 5-knot speed reduction for the minimum acceptable propulsion
load. Based on the lower speed requirements, which correspond to exponentially less resistance
and propulsion demand along the velocity-power curve, the concept has less dischargeable
power load available in both speed reduction conditions. Compared to the 30-knot concept, the
available load is 20-25% lower for the 27-knot concept case. Regardless of the difference in the
magnitude of the load available in all conditions, the relationship between the load available at
the time of delivery and the EOSL condition applies to the 27-knot concept, with a 98% increase
83
for a 1-knot reduction
and a 330% increase in the case of a 5-knot reduction. In summary, the 27-knot concept prints
lower dischargeable power flexibility in all cases and fails to provide the load threshold
available for the 15 MW2 load case in a 1-knot reduction in the transmission case, where the
30-knot IPS concept is capable of providing sufficient flexible power in the case of a 1-knot
reduction.
Table 15: IPS 27 knot Dischargeable Power – 1 knot Reduction
Propulsion
Conditions
Kw Propulsion
Conditions
Kw
LpREQ 27kt, 100% MCR 45,495 LpREQ 27kt, 100% MCR 45,495
Lpmin 26kt, Delivery 32,535 Lpmin 26kt, EOSL 40,669
Availabili
ty
12,959 Availabili
ty
4,826
Ladd (kW) DPF Ladd (kW) DPF
Load 1 2,000 1.00 Load 1 2,000 1.00
Load 2 15,000 0.86 Load 2 15,000 0.32
Load 3 30,000 0.43 Load 3 30,000 0.16
Table 16: IPS 27 knot Dischargeable Power – 5 knots reduction
Propulsion
Conditions
Kw Propulsion
Conditions
Kw
84
LpREQ 27kt, 100% MCR 45,495 LpREQ 27kt, 100% MCR 45,495
Lpmin 22kt, Delivery 19,830 Lpmin 22kt, EOSL 24,787
Availabili
ty
25,665 Availabili
ty
20,708
Ladd (kW) DPF Ladd (kW) DPF
Load 1 2,000 1.00 Load 1 2,000 1.00
Load 2 15,000 1.00 Load 2 15,000 1.00
Load 3 30,000 0.86 Load 3 30,000 0.69
While the flexible power capacity metric considers architecture-specific installed power
plants and electrical loading conditions, the flexibility of dischargeable power focuses only on
the demand load conditions, given the established system sizing criteria. Figure 11 graphically
shows the increase in load available when the propulsion load is discharged for the 27 and 30
knots concepts in their EOSL state. The area below each curve, constrained at the lower end by
the Lpmin velocity, is the available flexible power, as evaluated in the case in Table 13-16.
Horizontal gray lines are placed on three evaluation loads for 2, 15, and 30 MW. Where the
shaded area does not overlap with the horizontal line, the discharging power flexibility is less
than one, with the score decreasing as the distance between the two vertical arrows is drawn at
1 and 5 knot speed reductions, as evaluated above.
85
Figure 11: Flexible Power – Available Load with Speed
The metrics of dischargeable power flexibility for each of the eight conditions are plotted
in Figure 12 against the three additional load requirements (2, 15, and 30 MW). The figure
illustrates the point at which each case can no longer meet the additional load when the DPF
drops below one. The 30kt IPS concept outperforms the 27kt concept in every delivery/EOSL
combination and
-1/-5 knots of minimum propulsion load due to the exponential shape of the speed power curve.
The higher the sustained velocity required, the greater the load available when the minimum
propulsion load is identified along the exponential curve. In addition, as expected, we see that a
-5 knots reduction for the minimum propulsion load gives the greatest load and DPF value
available in each condition. Finally, the impact of the fact of expected life growth in the
propulsion load to achieve the minimum acceptable speed in the EOSL reduces the load and the
DPF available for an additional load of 15 and 20 MW in each case.
Power-Speed Flexibility
70,000
60,000
L-avail 27kt EOSL
L-avail 30kt EOSL
50,000
40,000
30,000
20,000
10,000
-
0 5 10 15 20 25 30 35
Speed (knots)
86
Figure 12: Flexibility of Dischargeable Power versus Available Load e.g. the case of speed delta
6.2 Distributable Power
The flexibility of the power distribution system is necessary to link the generating
capacity with the specific load demands of components throughout the vessel. Distribution
includes the transmission of energy flows throughout the ship and the conversion of energy
into the voltage and quality required by the end user, as shown in the logical view, Figure 8.
The physical configuration of the distribution system depends on the maximum distribution
capacity, the type and rating of available voltages, and the spatial considerations in which the
load is on board, which is usually limited by the assignment of electrical zones. Load
requirements will vary within each zone, depending on the interfaces required for each end
user. Therefore, the flexibility of power depends on the local conversion and distribution
capabilities of each zone.
Power Distribution System Flexibility Metric (PDSF). The power distribution system
Ladd (kW)
35,00030,00025,00020,00015,00010,0005,000-
0.00
0.20
30kt (-5kt EOSL)
27kt (peniriman -
1kt) 27kt (-1kt
EOSL)
27kt (delivery -5kt)
27kt (-5kt EOSL)
0.60
0.40
30kt (delivery -1kt)
30kt (-1kt EOSL)
30kt (-5kt delivery)
0.80
1.00
1.20
Discharge Power Flexibility

87
flexibility metric uses 'evaluation loading sets' to represent interface types and classifications of
potential future load requests within individual zones. The evaluation loading set is a
compilation of potential load elements in the future, beyond the initial system design
requirements for on-demand service at the time of delivery plus the required lifetime allowance.
Sets can be generated to include the various load characteristics required for service of the
power and energy system to be supplied, such as voltage type, voltage rating, and power draw.
Since the demand for propulsion loads for IPS vessels significantly exceeds the mission and
service loads of ships in any zone, they are considered separately from the distribution
evaluation loading set. Table 17 shows five evaluation loading conditions based on four potential
elements of the future mission and a representative set of their combinations. Each load element
is differentiated based on the type of voltage and power demand. The ~1000 VDC demand is
typical of high-power mission systems such as radar and laser weapons and can be taken
directly from the main power distribution bus. Other low-voltage demands, such as onboard
computing and thermal auxiliary systems, require conversion and distribution of power within
zones within a secondary power distribution system. In the exploration of the early-stage design
trading space, full permutations of single elements and combinations thereof can be used to
define simple and indicative metrics for the flexibility of distributable power. Further in the
design process, ship configuration details such as general settings and mission station locations
are established, and evaluation loading sets must be adjusted to reflect the revised open trade
space or uncertainty for specific zones.
Table 17: Example of an 'evaluation loading set' distribution system for potential future load
requests
88
Voltage
Type:
1000 VDC 800-650 VAC 450 VAC
Load
Condition
(N)
Element*
(Power -
kW)
Element
(Power - kW)
Element
(Power - kW)
N1 Lasers (1200) Base Load (500) Base Load (2000)
N2 Radar (1000) Base Load (500) Base Load (2000)
N3 EW (1500) Base Load (500) Base Load (2000)
N4 NA
Base Load (500)
Energy Magazine
(1000)
Base Load (2000)
N5
Lasers (1200)
Radar (1000)
EW (1500)
Base Load (500)
Energy Magazine
(1000)
Base Load (2000)
* Electrical loads for interesting mission system elements taken from (ESRDC, Ship Concept Alternatives,
2017)
The distribution capacity within a zone depends on the size of the primary power
distribution system, which carries the intermediate voltage power from the onboard generator,
and the secondary power distribution system, which converts the intermediate voltage power
into lower voltages and currents that are directly compatible with the end-user demand. Power
distribution systems can be configured in a variety of topologies, such as radial, distributed, or

89
zonal buses, with each option having sacrifices in space, weight, cost, and performance.
Flexibility of ship power distribution system (PDSF), Equation (3), is the average of the
flexibility of each zone
(DSTzone ): the amount of flexibility of each zone, divided by the total number of zones
(Nzones ). Equation (4) determines the flexibility score of each zone by assessing the ability of
the distribution within the zone to meet a set of load conditions (N). If the zone has sufficient
capacity in all categories of the specified rating criteria, (Nj) will be rated as 1, otherwise, if the
distribution architecture cannot satisfy any of the categories under load conditions, the zone will
receive 0.
This approach provides a measure of platform distribution flexibility, regardless of
total number of electrical zones, as described below in Section 6.2.1.
0
90
PDSF =
DST Zone
∑zone(s)
DSTzone
Zone
= N1+N2+N3+⋯
+Nj
Note
(3)
(4)
Flexibility can be combined (and purchased) as capacity in the design on the initial delivery
of the system, or through design preparation that allows for future system upgrades when
needed. Primary and secondary power distribution configurations (ring, distributed, zonal, or
other) control the capabilities inherent in the system that affect flexibility, as measured in
equation (4). Table 18 provides three examples of power distribution system features that allow
for flexibility by increasing the total number of potential load cases either on the initial system
delivery or as a future reconfiguration. Section 6.2.1 provides case studies comparing split rings
and zone distribution system architectures at different stages of the design specification process,
and different points in the platform's lifetime. Section 6.5 will outline the use of real options to
differentiate between the value of installing capacity in advance of the design representative in
the ability to upgrade the system in the future after the disruption has been realized.
Table 18. Examples of flexible distribution system features
91
Flexible Electricity Distribution Impact
The electric power distribution bus is
dedicated to the expected high power
load.
Increase the number of potential load cases by
allowing new mission system elements to be installed
in any zone, with
reduce dependence on power conversion capacity
within zones.
The use of HTS cables – variable
current, depending on temperature.
It can increase the power distributed to the zone by
lowering the temperature of the cable without adding
new cables. Requires additional cooling. (Note: not
necessarily available
instantaneous, design preparation is required)
Use of programmable and/or modular
power conversion and power
electronics:
-Power Electronic Building Block
(PEBB)
-Integrated Power Node Center
(IPNC)
Reduce the total number of power conversion
elements. Provides the ability to tailor conversions
within a specific zone to the needs of future end users
using or
general distribution equipment.
6.2.1 Case 3: Power Distribution System Flexibility Metrics
This case shows how to build an evaluation loading set and use it to assess the flexibility of
a power distribution system in a P&E system architecture.
Conventional split-ring bus architecture (early-stage design): based on the
concept of a 10,000-ton IPS ESRDC vessel (Smart, et al., 2017)

92
Alternative ring bus (later design stage): a variant of the ESRDC concept case
is presented to demonstrate the maturation of the evaluation criteria as the design
space for potential future loads is reduced.
Zone distribution architecture (base model): based on the Integrated Fight-
Through Power (IFTP) concept described in the 'Next Generation Integrated Power
System Roadmap (NGIPS)' (Doerry, 2007)

93
Zone alternatives (future block upgrades): variants of the NGIPS concept are
used to show the increased flexibility associated with future upgrades to the initial
base architecture.
The evaluation loading set is built as a full permutation of each element load in Table 19,
which includes the base load required on the delivery plus any potential future mission systems
that may be required to be hosted by the platform in the future. The voltage type and power
ratings for this evaluation set are notional in nature, based on the payload list identified in
(Smart, et al., 2017), and do not represent the actual value of the Navy system. Elements listed
with multiple power ratings, separated by commas, represent different configurations that future
systems may reflect. The various options per element type can represent the uncertainty of the
ranking or quantity of the elements. The two baseload LVAC options reflect potential
differences in multiple ship zones during delivery. The inclusion of a zero kW element load
allows the evaluation set to take into account potential zone requirements that do not include a
given mission element. The full permutation of these load elements results in 1,728 evaluation
conditions, which are provided in Appendix A; each of these evaluation conditions is assessed
against each zone in a given distribution system architecture to determine the distribution score
for that zone, then the zone scores are combined for the overall PDSF metric. To simplify the
assessment of a particular electrical distribution zone, the load applicable to each set is summed
up by the voltage type category, in this case as 1000V Medium Voltage Direct Current
(MVDC), between 650-800V Alternating Current or Direct Current (MVAC/MVDC), or 450V
Low Voltage Alternating Current (LVAC). For example, the 300th permutation consists of:
[500 kW MVAC/DC Base Load, 1500 kW LVAC Base Load, 200 kW MVAC/DC Energy
Magazine, 600 kW MVDC Laser, 0 kW MVAC/DC Processing, 0 kW MVAC/DC VLS, 1700
94
kW mvdc Radar, 4000 kW MVDC Wipe, 450 kW MVAC/DC Sonar
which amounts to [6,300 kW MVDC, 1,150 kW MVAC/DC, 1500 kW LVAC].
Table 19: Evaluation Load Set Elements
Voltage Type: MVDC (direct pass)MVAC / MVDCLVAC
Element Power (kW) Power (kW) Power (kW)
Base Load NA 500 1500, 2000
Energy Magazine NA 0, 200, 1000,
2000
NA
Laser 0, 600, 1200 ON ON
Processing Equipment ON 0, 200 ON
Missile Launcher ON 0, 400 ON
Radar 0, 1700, 3300 ON ON
Electronic Warfare (EW)0, 2000, 4000 ON ON
Sonar ON 0, 450 ON
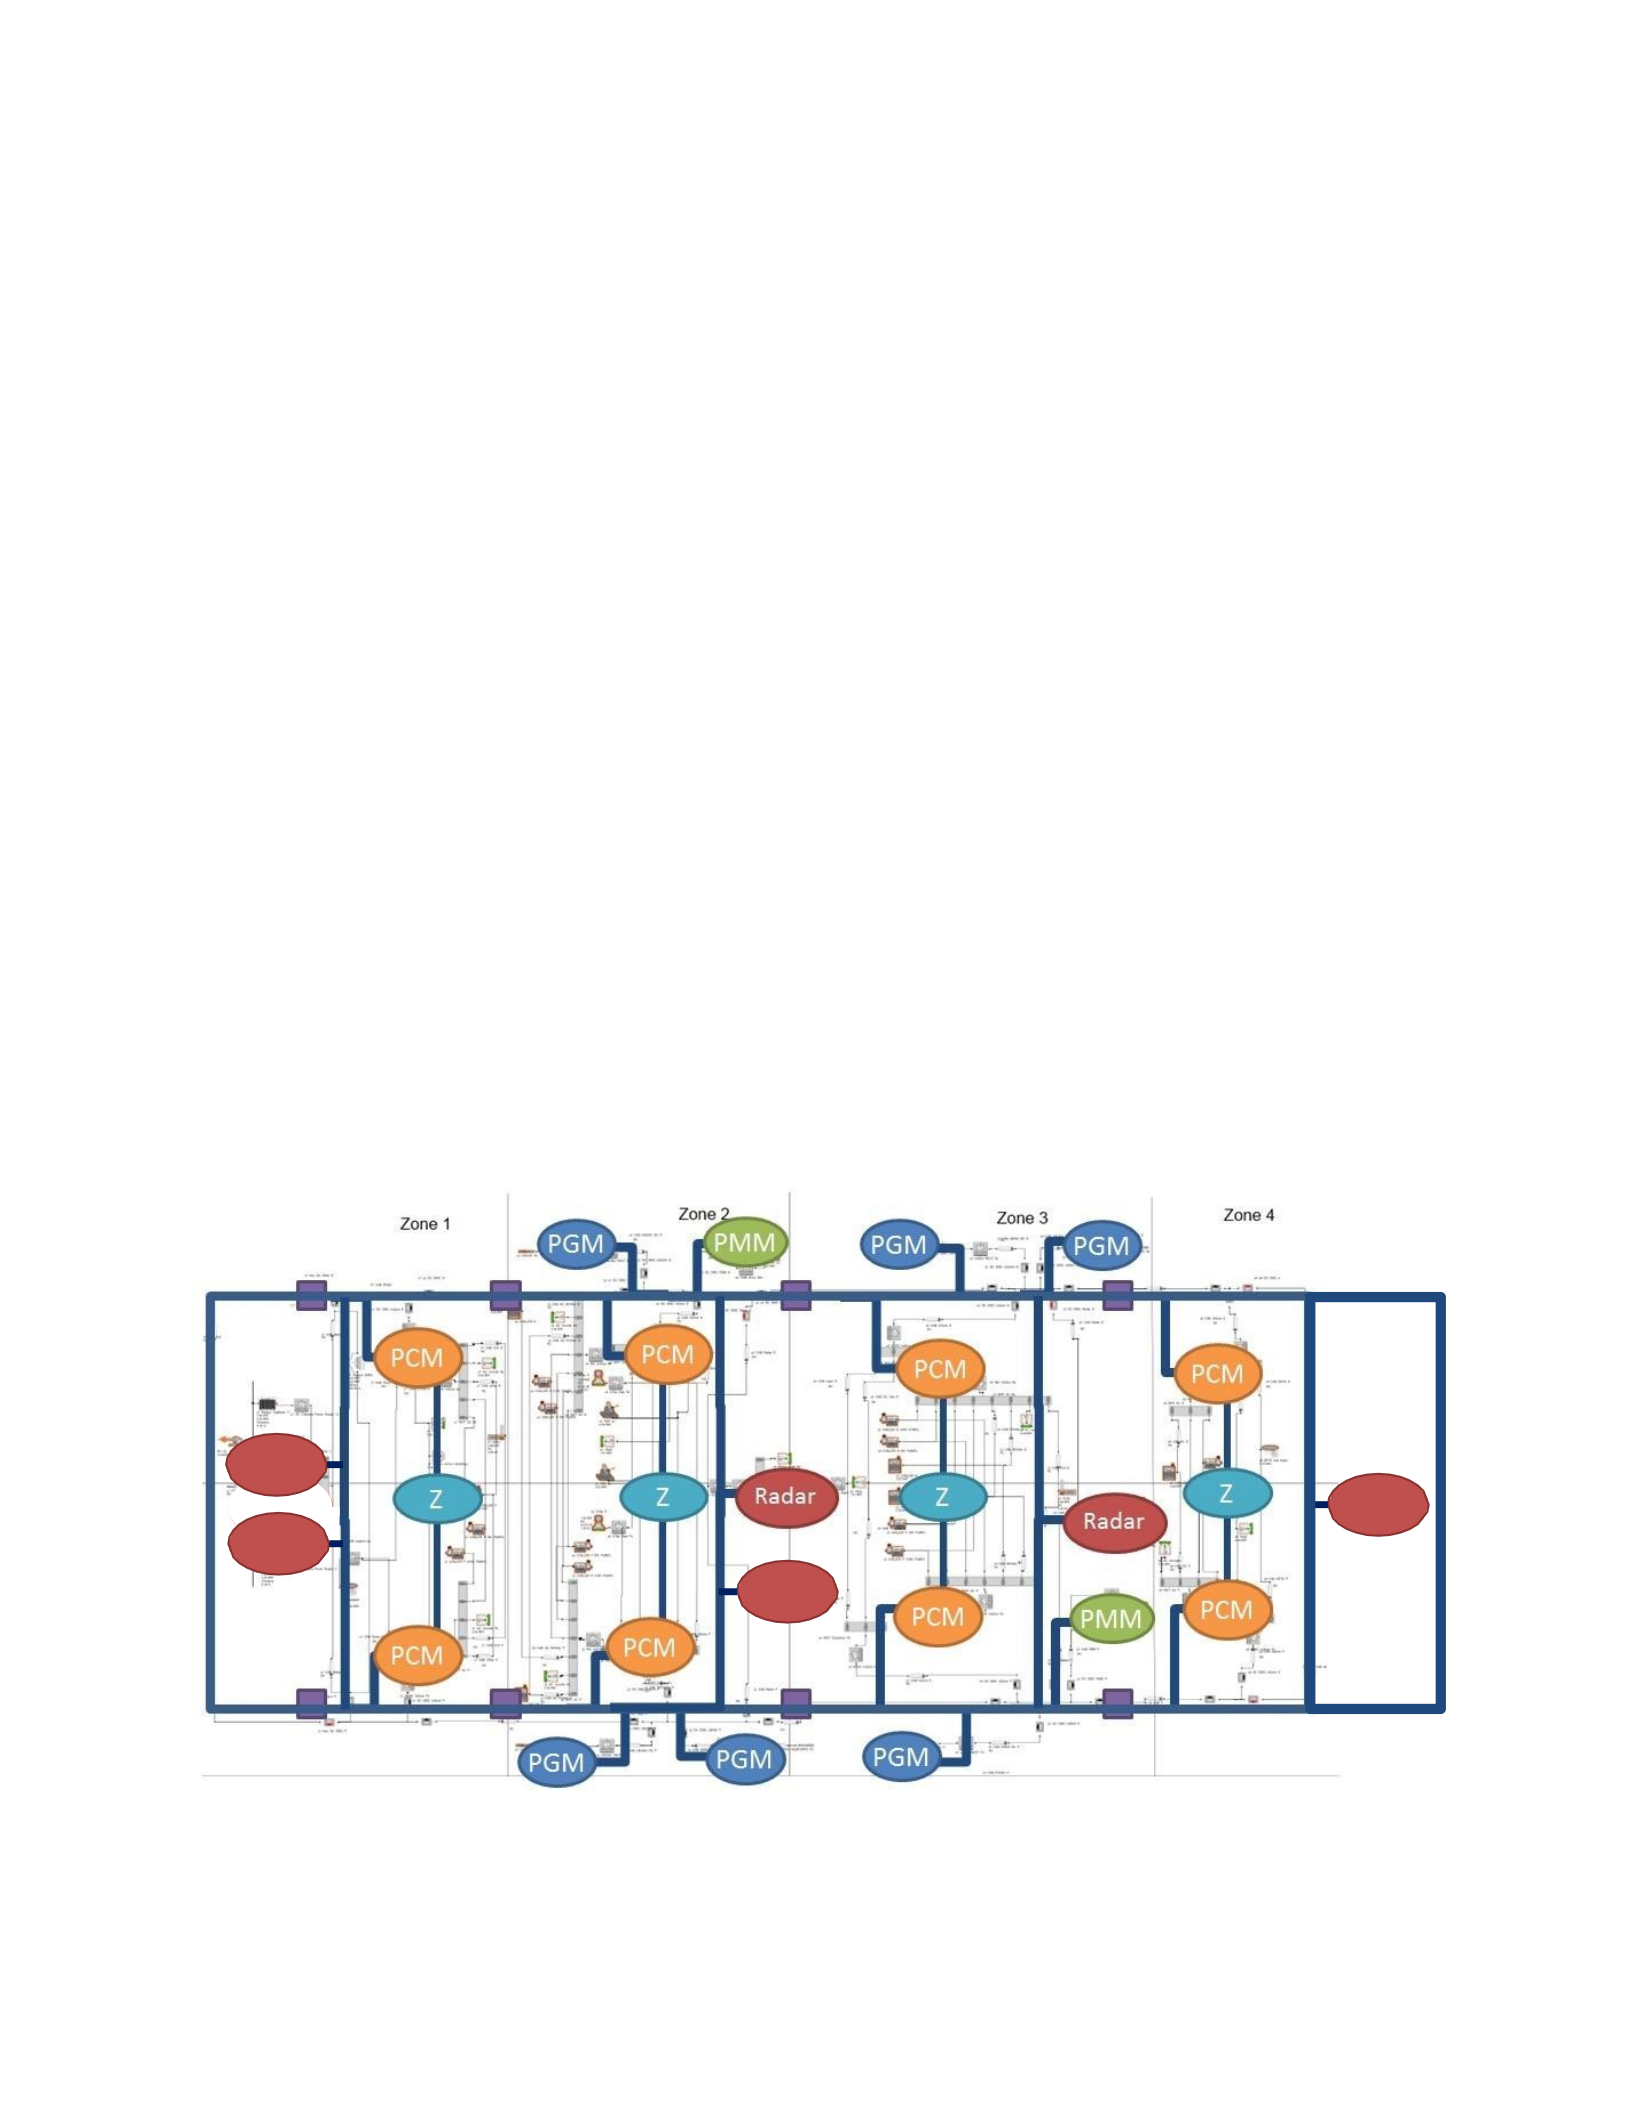
95
Variant 1: Ring Bus (initial stage design evaluation). The conventional split-ring-bus
architecture, shown in Figure 13, is based on the 10,000-ton IPS concept (Smart, et al., 2017),
with four electrical distribution zones, a 10 kVDC primary power distribution system voltage,
and dual power lines on the port and right sides of the ship via a fully connected ring bus. The
power generation module (PGM) and the propulsion motor module (PMM) are connected
directly to the ring bus via a corresponding converter or drive. The basic architecture includes a
dedicated converter for high power loads to connect two Radars and one Railgun to the main
distribution bus; however, for this case and the evaluation load set, the topology was modified
to replace the Railgun converter with a converter for EW and Laser elements in Zone 1, add a
second EW converter in Zone 2, and add a second Laser converter in Zone 4. The power
conversion module (PCM) represents the converter and inverter in each zone, connecting all
other loads to the port and the right bus. The size of these converters is taken directly from the
ESRDC concept, and the total distribution capacity by zone is summarized in Table 20.
EW
L
L
EW

96
Figure 13: Topology of the Conventional Split Ring Bus Distribution Architecture. Based on
(Smart, et al., 2017).
Each of the four electrical zones was independently assessed for its ability to meet 1,728
potential future electrical loading conditions (N) in the evaluation set. If the zone has sufficient
capacity in each of the three voltage categories, then a score of 1 is recorded for that Nth
condition, otherwise, if there is insufficient capacity in any of the three categories, a score of 0
is recorded. The sum of the 1,728 N-scores divided by the total number of load conditions N
determines the zone flexibility metric (DST zone), as shown in Table 20. The average score of
the four zones determines the total flexibility score of the power distribution system (PDSF) of 0.31.
97
With a PCM converter and inverter rating specified for the ESRDC concept, all four zones
are able to accommodate the maximum MVAC/MVDC and LVAC load combinations, given the
converter duplicate sets for ports and the right bus for redundancy. If the analysis is performed
assuming that only one set of PCMs is used at all times in each zone, zone 4 will not be able to
accommodate the maximum loading conditions in this voltage category and a score of 0 for this
N condition; All other zones can handle the maximum rating in these conditions with a set of
converters.
In each of the four zones, the delimiter distribution category is the MVDC converter rating
for the specific mission element. In design space exploration activities, these findings may lead
designers to investigate the ability of potential future elements to bring in additional specialized
converters when needed for future installations, along with verification of the architecture's
total flexible power capacity.
Table 20: Distribution Capacity of Conventional Split Ring Bus by Zone and voltage category;
with the distribution flexibility score of each zone taking into account
the permutation of the full evaluation loading set.
Zone 1
(kW)
Zone 2
(kW)
Zone 3
(kW)
Zone 4
(kW)
MVDC
(direct feed)
3,200 3,700 3,300 1,200
MVAC /
MVDC
8,000 17,800 12,400 5,800
LVAC 4,200 5,800 7,000 3,100
98
DST Zone 0.33 0.41 0.37 0.11
*Distribution capacity based on (ESRDC, 2017)
Variant 2: Ring Bus (later stage design evaluation). To simulate the progression from
the analysis of distribution flexibility from the early-stage concept design to the more mature
initial design baseline, the conventional ring bus architecture is used for the evaluation of the
second flexibility. In this case, the design space for potential zone requirements is narrowed and
the evaluation loading set is tailored to the requirements for each zone. Table 21 provides
refined requirements for evaluation loading determination criteria applicable to Zones 1-4. Zone
1, the foremost zone on the ship, was designated as the responsibility for the Sonar, due to the
formation of the hull shape and the location of the sonar dome. Radar requirements are allocated
to zones 2 and 3, which are covered by a deckhouse for mounting equipment at the top. The
Laser trading space does not change; however, the energy magazine requirement is reduced to 1
MW and the location is based in zones 2-4. The resulting increase in the flexibility score is
shown in Table 21, and the total power distribution system (PDSF) flexibility score increases to
0.64.
Note that zone 1 scored 1.0, as the evaluation loading set requirements were narrowed down to
match the MVDC converter for mission elements as intended.
99
Table 21: Enhanced Requirements Evaluation Loading Criteria
Zone 1 Zone 2 Zone 3 Zone 4
MVDC Limiter
Criteria (live
pass)
0x Radar
1x Unit EW
1x Laser
Maks
1x Unit
Radar 1x
Unit EW 1x
Laser Maks
1x Unit
Radar 1x
Unit EW 1x
Laser Maks
0x Radar
1x Unit EW
1x Laser
Maks
MVDC (kW) 3,200 4,900 4,900 3,200
MVAC / MVDC
Restriction Criteria
1x Sonar
0x Energy Mag
0x Sonar
Mag Energi <1MW
0x Sonar
Mag Energi <1MW
0x Sonar
Mag Energi <1MW
MVAC/MVDC (kW) 1,550 2,100 2,100 2,100
LVAC (kW) 2,000 2,000 2,000 2,000
DST Zone 1.0 0.65 0.59 0.33
Variants 3 and 4: IFTP (Future Block Base and Upgrade Model). The zone
distribution architecture is based on the concept of Integrated Fight-Through Power described in
the Roadmap of Next-Generation Integrated Power Systems (Doerry, 2007), with the notional
topology within the zones depicted in Figure 14. For this, the concept of a zone electricity
distribution system consists of 4 electrical zones, with a series of types of Power Conversion
Modules (PCMs) to convert power in each zone. The PCM-4 serves as a transformer rectifier to
convert MVAC power from the power generation module to 1000 VDC for distribution throughout
the ship. Within each zone, the PCM-1A converts 1000 VDC power into a variety of MVDC
voltages based on user needs. The PCM-2A then converts the 750-800 VDC power from the PCM-
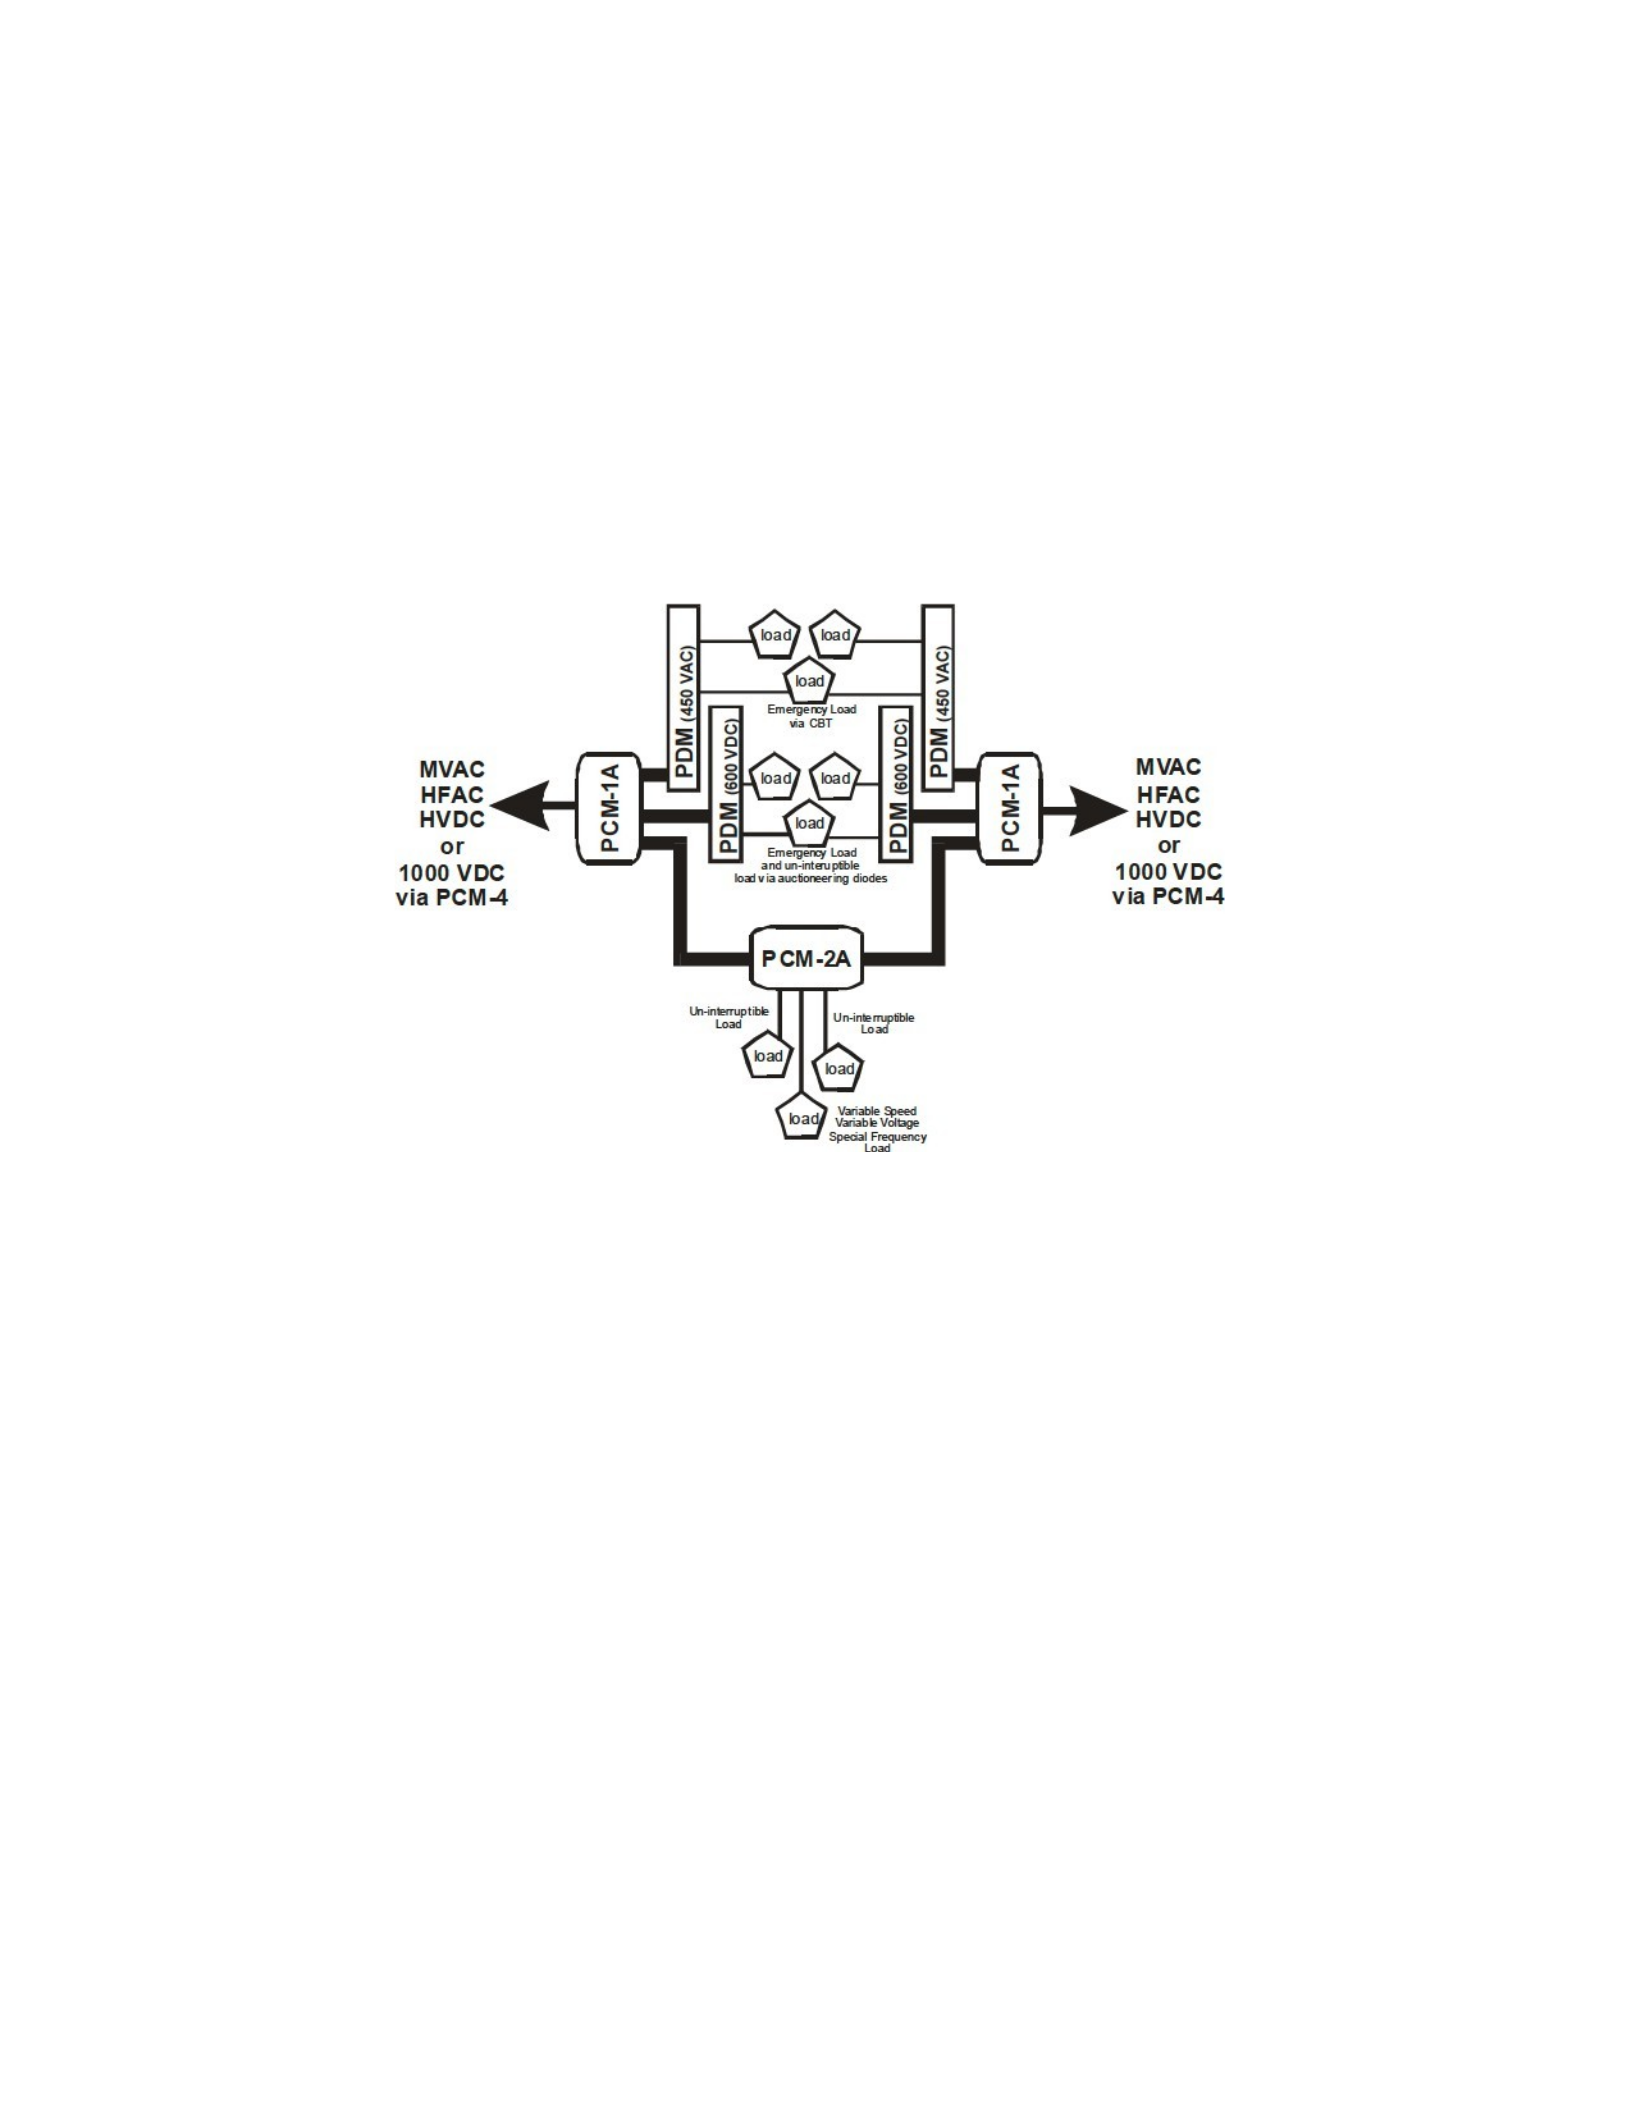
100
1A into demand within the LVAC zone. In addition, for this concept, the notional PCM-X is
connected to a 1000 VDC bus in each zone to serve the high-power MVDC load throughout the
vessel. It is assumed that the rating of each PCM is scalable based on the number of modular
subcomponents included: the Marine Service Inverter Module (SSIM) or the Converter Module
(SSCM).
Figure 14: NGIPS Roadmap "Topology in Future Potential IFTP Zones" (Doerry, 2007)
101
Two variants of the IFTP zone concept were evaluated to demonstrate different
assessments of the flexibility associated with the architecture of the base model as originally
delivered, and the future block architecture, including several planned upgrades to the
distribution system. Section 6.5 will discuss the method for designing in "Real Options", which
requires flexible design preparation with the aim of reducing the upfront costs and risks
associated with the uncertainty of future load demand. Both variants of zonal IFTP are
consistent with this approach, as the basic model architecture includes design preparation in the
form of planned PCM growth capacity to accommodate additional SSIM/SSCM in the future, if
needed. The base model was delivered with a capacity of 5.5 MW PCM-X, 12 MW PCM-1A,
and 10 MW PCM-2A, and design preparation for the 22 MW PCM-X and 4 MW PCM-1A
SSCM/SSIM. Table 22 shows the PCM capacity for the base model configuration by zone, with
the associated zone flexibility metric (DSTzone). The total power distribution system flexibility
score (PDSF) for this configuration is 0.14. However, once the maximum PCM capacity is
installed in a future block configuration, as shown in Table 23, the total PDSF score increases
to 0.85.
Table 22: Distribution Capacity of IFTP Base Model Zones by Zone
Zone 1 (kW) Zone 2 (kW) Zone 3 (kW) Zone 4 (kW)
PCM-X 0 2,000 3,500 0
PCM-1A 3,000 3,000 3,000 3,000
PCM-2A 2,500 2,500 2,500 2,500
DST Zone 0.03 0.16 0.32 0.03
102
Table 23: Future Distribution Capacity of IFTP Blocks by Zone
Zone 1 (kW) Zone 2 (kW) Zone 3 (kW) Zone 4 (kW) Total DST
Capacity (kW)
PCM-X 6,875 6,875 6,875 6,875 27,500
PCM-1A 4,000 4,000 4,000 4,000 16,000
PCM-2A 2,500 2,500 2,500 2,500 10,000
DST Zone 0.85 0.85 0.85 0.85 0.85
The flexibility metrics of the power distribution system of the four architectural variants
and the flexibility scores of individual zones are plotted in Figure 15. Each architecture is
modeled with four electrical zones, with distribution and conversion capacities varying in each
zone, across the MVDC, MVDC/MVAC, and LVAC assessment categories. Ring bus variants,
each with the same distribution and conversion capacity, are shown in blue. The early-stage
design assessment uses the full permutation of the evaluation load set, while the later stage
design assessment adjusts the evaluation load based on other known design decisions to reduce
the range of potential future load options desired in each zone. This maturation of design data
resulted in a 100% improvement in PDSF for ring bus architectures. The base model of IFTP
and future block variants are plotted in yellow, to demonstrate the increased distribution
flexibility provided by incorporating preparation in the design to accommodate the future
103
(long-term) interruptions in the required load demands. The vessel concept for this IFTP variant
remains constant in addition to the installation of additional distribution and conversion
modules in future blocks, to represent an in-line increase in maintenance availability in the
same way where new load demand end-users are installed. In the exploration of design spaces,
a large number of representative architectures can be determined by the characteristics of their
respective zones, and are assessed against a series of general evaluation burdens to identify
viable options. In this limited example, the IFTP option is preferred based on the lower upfront
architectural cost and the ability to achieve higher flexibility of the power distribution system in
the future, when long-term disruption is realized.
432
Electrical Zone
1
Overall
Concept
0.00
0.20
0.40
0.60
0.80
IFTP (Basic Model)
IFTP (Future Block)
1.00
Ring Bus (later variant)
DST Zone
Ring Bus (early)
1.20
Power Distribution System Flexibility
PDSF
Distribution Flexibility
Systems/Zones

0
104
Figure 15: Power Distribution System Flexibility Score (PDSF) and individual zones (DSTzone)
6.3 Energy Storage
The flexibility of an energy storage system (ESS) provides the ability to respond to
disturbances with unique demands or load constraints in the operational view of the power and
energy system. The Naval Power Systems Technology Development Roadmap (McCoy &
Kuseian, 2013) identifies the need for energy storage to address "pulse power support for
advanced weapons and sensors, load balancing, emergency power, and generator transient
support and fuel economy initiatives." The demands of these missions, including advanced laser
weapons and radar systems, pose new challenges for P&E systems in terms of power loading
profiles, requirements for stable power cleanliness, and quality of service. In the view of a
logical system, energy

105
Storage systems focus on power capacity and power quality disruptions that impact the
upstream energy storage needs in the energy flow between supply and demand loads. Energy
storage can be placed within a primary or secondary power distribution system, depending on
its intended operational use and balanced with system integration and cost impact.
Energy Storage System Flexibility (ESSF) Metric. Like the flexibility of distribution in a
zone, ESS flexibility (ESSF) is determined by assessing the ability of an energy storage system
to meet each load scenario (S), equation (5). If the ESS has a maximum power rating and total
energy capacity to serve a load scenario, (Sj) will be rated as 1; otherwise, if it cannot meet the
total energy required, it will receive a value of 0. The set of load scenarios can be generated as a
combination of the demands of individual elements, such as complete set permutations,
variations in element peak shaving assumptions, uncertainty limits from stochastic modeling, or
with informed CONOPS requirements. The sum of the scores from the individual load profile
scenario assessment assessments is then divided by the total number of scenarios (Stots) to
provide a total measure of the platform's energy storage flexibility.
ESSF = S1+S2+ +Sj⋯
Stot
(5)
Power profiles for high energy loads and changes in the operating requirements of
propulsion systems and power plants can be modeled as an extension of the evaluation load set
developed for the flexibility of distributable power. In addition to the type and magnitude of
load used in Section 6.2, the operational scenario for assessing the flexibility of an ESS requires
a load profile to determine the load behavior, such as stochastic or pulse load, over a specified
duration. Table 24 provides an example of a load profile for an element that requires ESS

106
services, based on a model proposed by the MIT Sea Grant (Tavagnutti, Chalfant,
Chryssostomidis, & Hernandez, 2023).
Compared to a distributable power evaluation set, the load profile has been expanded beyond a
single-zone focus to account for ship-wide configurations, including scenarios that require
energy storage for propulsion and ship service load reserves, referred to as spinning reserves.
The assumptions for the power demand and energy of this load profile, including the peak
shaving approach, will be discussed in detail in Case 4, Section 6.3.1. Additional load profiles
can be generated to account for mission load variations through stochastic modeling, such as
the method specified by (Stevens, Opilia, Cramer, & Zivi, 2015).
107
Table 24: Example load profiles for potential future operational scenarios that require energy
storage flexibility
Element
Types of
Operational
Behavior
Operatio
nal
Duration
Power -
Peak
(kW)
Stable
Bus
Load
(kW)
Peak Shear
Load (kW)
Max ESS
Energy Demand
(kWh)
Radar
Continuously
Stokastik 4200 1000 727.5 272.5 0.06
Laser
Intermittent
Stokastik
1800 1200 200 1000 92.3
Electronics
Warfare
(EW)
Continuously
Stokastik 4200 1500 950.3 549.7 0.79
Spinning
Reserve
Continuously
Deterministic 300 2000 0 ON 238
ESS recharging is considered in the definition of each individual operational scenario
demand based on the energy demand of the element over time, and the determination of the
power that can be drawn from the ship's power distribution system. Balancing the flexibility
performance of an ESS in the desired scenario against the cost of acquiring and integrating
vessels for a range of design alternatives will inform the decision to pursue a dedicated (point-
of-use) or integrated energy storage solution. This metric can be used to assess the flexibility of
108
specialized and integrated energy storage architectures.
6.3.1 Case 4: Energy Storage System Flexibility Metrics
This case study evaluates the energy storage flexibility of the notional Energy Storage
System design space. One hundred and twenty-five individual ESS architectures, listed in
Appendix B
determined based on their withdrawal from the ship's power distribution bus, its energy
capacity, and maximum power rating. The design space is generated as the complete set of
discrete parameter combinations defined in Table 25.
Table 25: Space Divider Parameters of Notional Energy Storage System Design
Bus
Capacity
(kW)
Energy Storage
Capacity (kWh)
ESS Puncak
Power (kW)
1 200 1 1,000
2 2,000 10 1,600
3 3,250 100 2,200
4 4,500 250 3,000
5 5,000 300 3,200
The operational scenarios used to evaluate the design space are based on the element load
profile established by (Tavagnutti, Chalfant, Chryssostomidis, & Hernandez, 2023), and do not
reflect the actual performance of the Navy's systems. Columns two through six of Table 26
define five operational scenarios related to mission profiles of the three types of element loads

109
and spinning reserves for the ship's power reserves. Two element loads, the Radar and Electronic
Warfare elements, are assumed to operate in a "peak shave" profile, where the average power
Requests for operating profiles are taken directly from the ship's power distribution bus and
The ESS is responsible for fluctuations in demand above and below this average. When actual
110
The demand exceeds the supply of the distribution bus, the ESS releases the required energy
delta, and when the demand is below the bus supply, the ESS uses the load delta to recharge.
The third element, the Laser gun, relies solely on the ESS for energy supply during its active
operating time, with a constant withdrawal of 200 kW from the bus to cover the standby
conditions between shots. The "combination" scenario takes into account the simultaneous
operation of three types of individual element loads. The three elements and their combination
scenarios are stochasticly modeled in MATLAB, 7.1Appendix C , for a seventy-minute
operation period, as defined by (Tavagnutti, Chalfant, Chryssostomidis, & Hernandez, 2023).
The last scenario, the "spinning reserve", is modeled separately. For this case, a simulation of
ten runs is run for each scenario to provide an overview of the impact of stochastic variability,
with output power
and energy profiles as depicted in Appendix C Table 26 provide the average power and energy
characteristics of each individual element simulation and system-level attributes including the total
number of elements of each type. For combination scenarios, the maximum rating of each of the
included elements is adjusted to match the number of included elements.
Table 26: Case 4 Operational Scenario for Energy Storage Flexibility
Element
:
Radar Laser Electronics
Warfare
(EW)
Spinning
Reserve
Combinatio
n
Number of
elements
in the System
3 1 2 ON 6 (included)
111
Modeled
Operational
Behavior
Continuous
active stochastic
noise
Basis Sinusoid
Stochastic Intermittent
pulse length and
Event
Continuum,
Stochastic
Continu,
Deterministi
c
Combine
d,
Stochast
ic
CONOPS
Scenario
Duration (s)
4200 1800 4200 300 4200
Individual Element Attributes
Peak Power -
Single Element
(kW)
1000 1200 1500 2000 7200
Stable Bus Load –
Single element
(kW)
727.5 200 950.3 0 4352.4
Peak Shaving
Power –
Single element
(kW)
272.5 1000 549.7 ON 2847.6
Ess Energy
Demand Max –
Single Element
(kWh)
0.06 92.3 0.79 ON ON
System-level attributes – all elements included
112
Total Bus Load –
All
Element (kW)
2182.5 200.0 1900.6 0 4352.4
ESS Max Power –
All Elements (kW)
817.5 1000 1099.4 2000 2847.6
Total ESS Energy
– All Elements
(kWh)
0.18 92.3 1.58 238 99.5
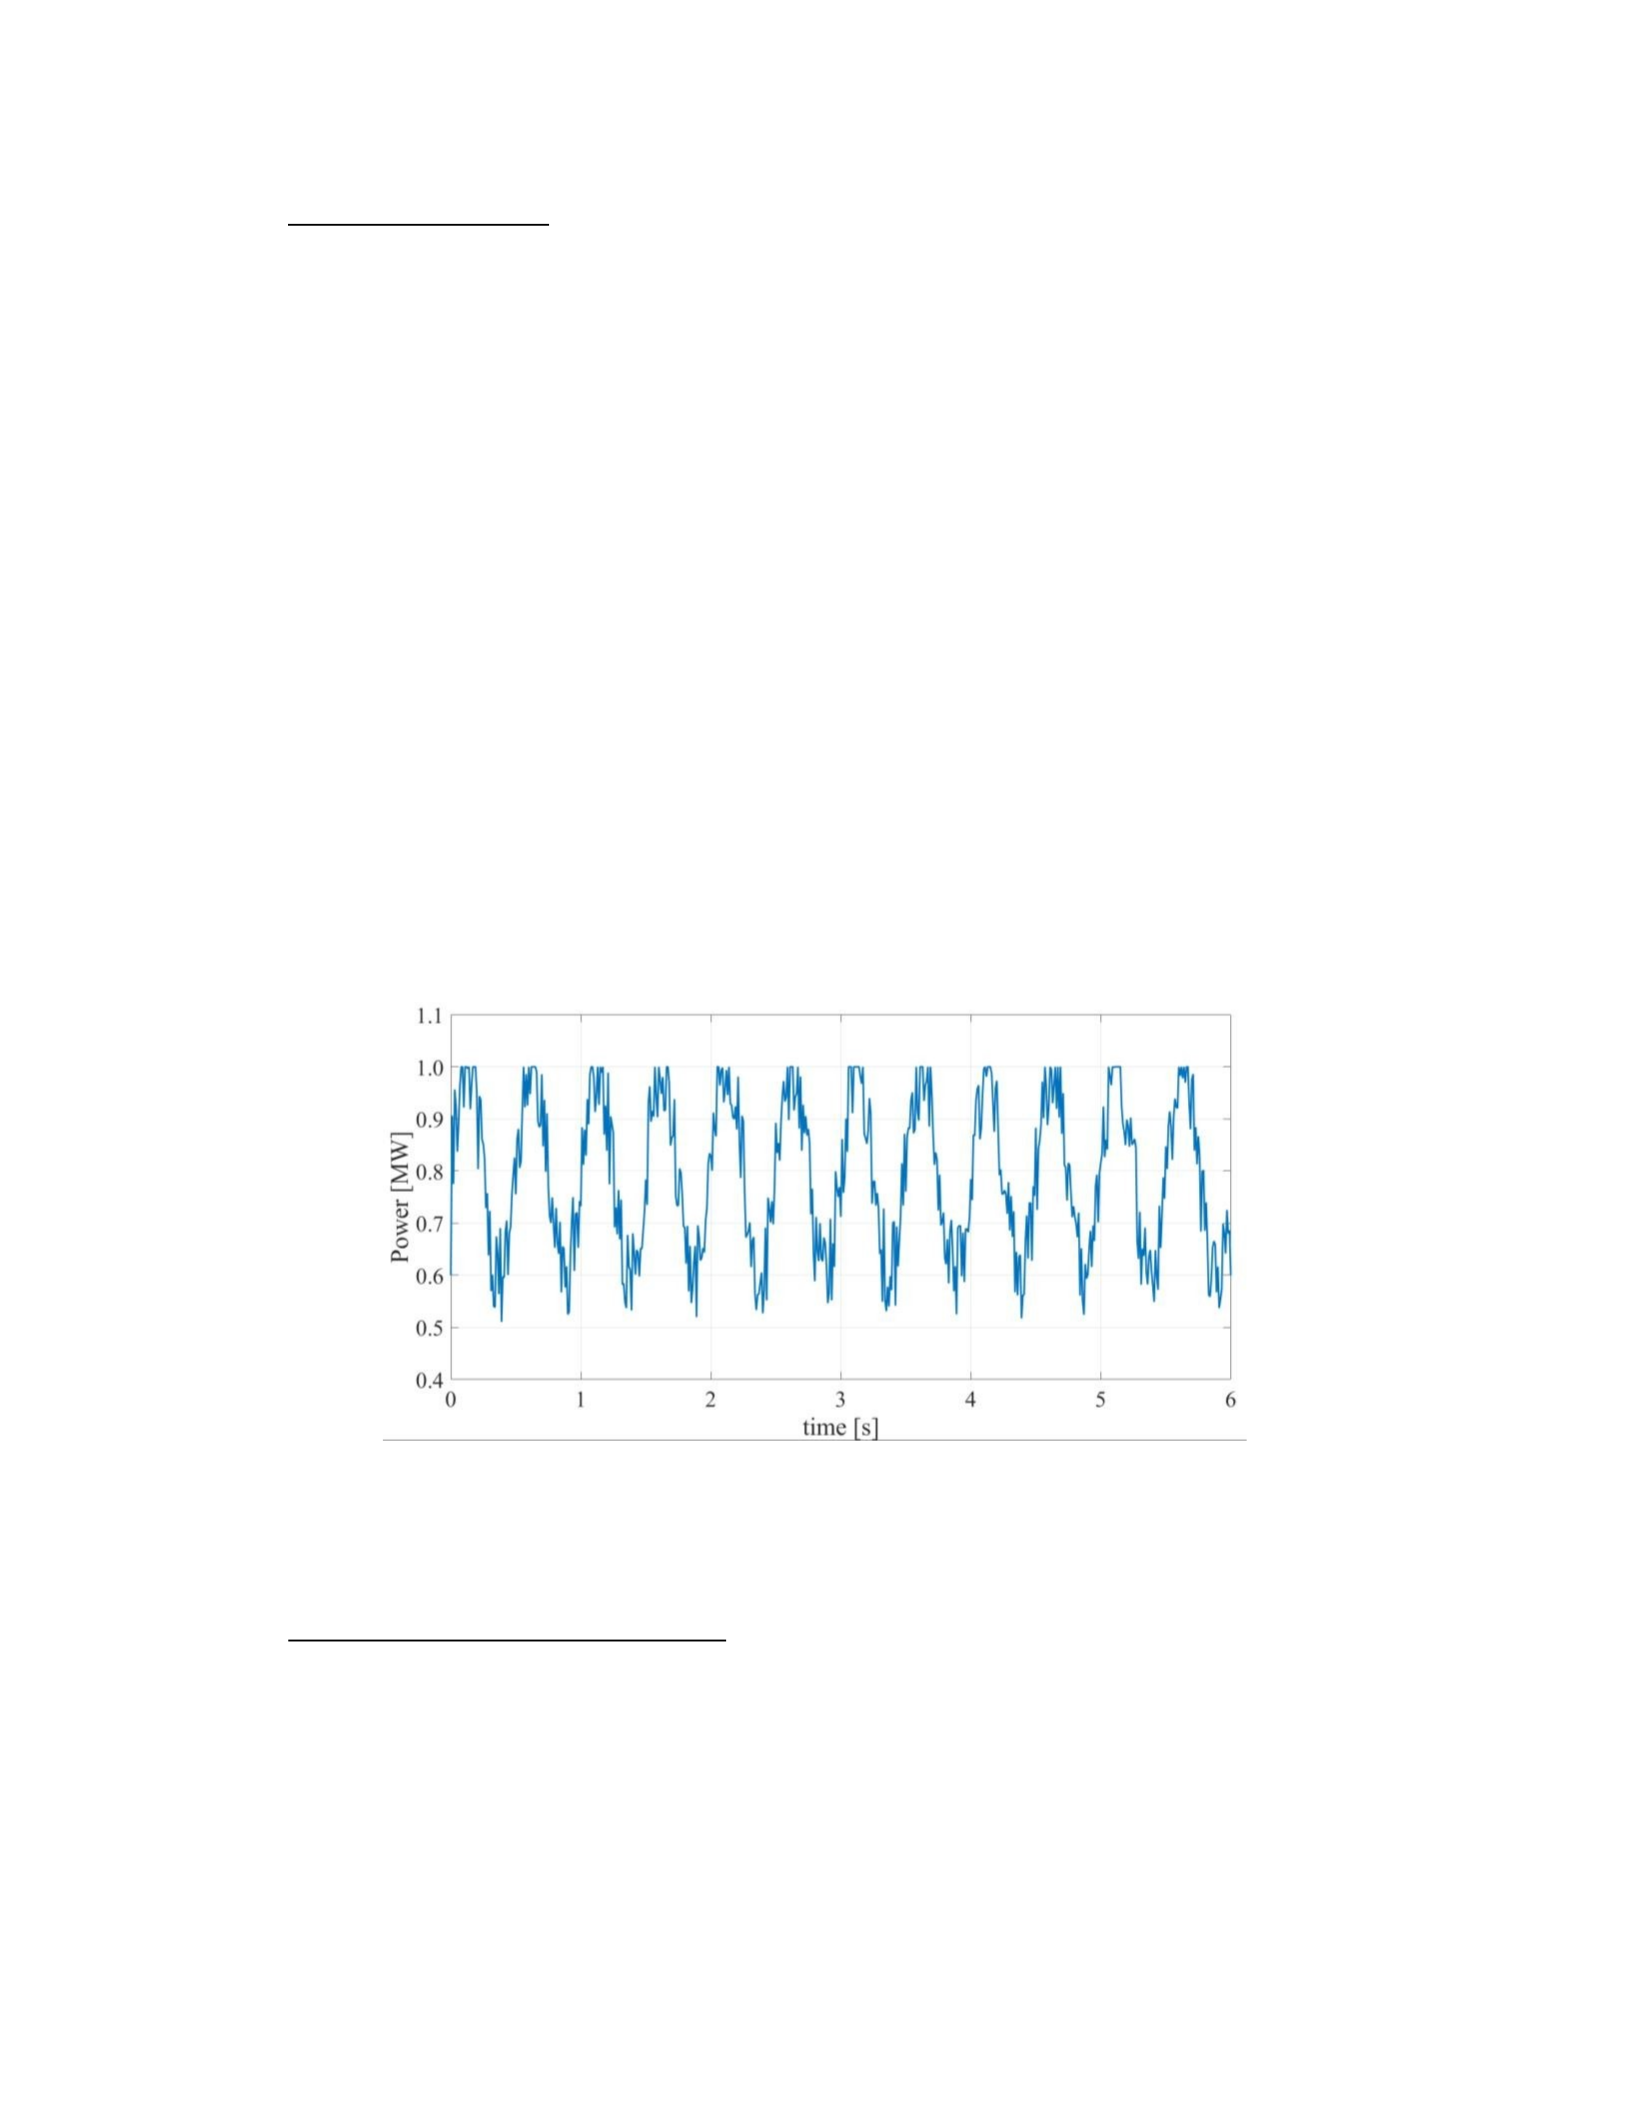
113
Radar Mission Load : Modeled as a sine wave with a maximum power of 1000 kW, Image
16. The operating profile runs continuously for the duration of the seventy minute
mission, with stochastic variability added as "noise" at each time step. The Radar
demand on the ESS is based on the peak shaving assumption, with the ESS responsible
for supplying the difference between the operational Radar power demand and the bus-
supplied power. Energy is the power over time, calculated at each step of time in the
profile. The maximum energy is found from the sum of energy requirements at each step
of time. While the determination of bus power as the average radar demand will
theoretically lead to an even amount of energy charged and discharged, stochastic noise
modeling provides an opportunity for energy demand to accumulate beyond a maximum
of one sinusoidal discharge cycle.
Figure 16: Radar power profile (Tavagnutti, Chalfant, Chryssostomidis, & Hernandez, 2023)
Electronic Warfare Mission Load : Modeled as a random instantaneous load between a
maximum power of 1,500 kW and a minimum power of 400 kW, Figure 17. The
operating profile runs continuously over the duration of the seventy minute mission,
with stochastic variability incorporated into the operational EW power demand at each
time step. The EW demands on the ESS maintain the same assumptions for peak
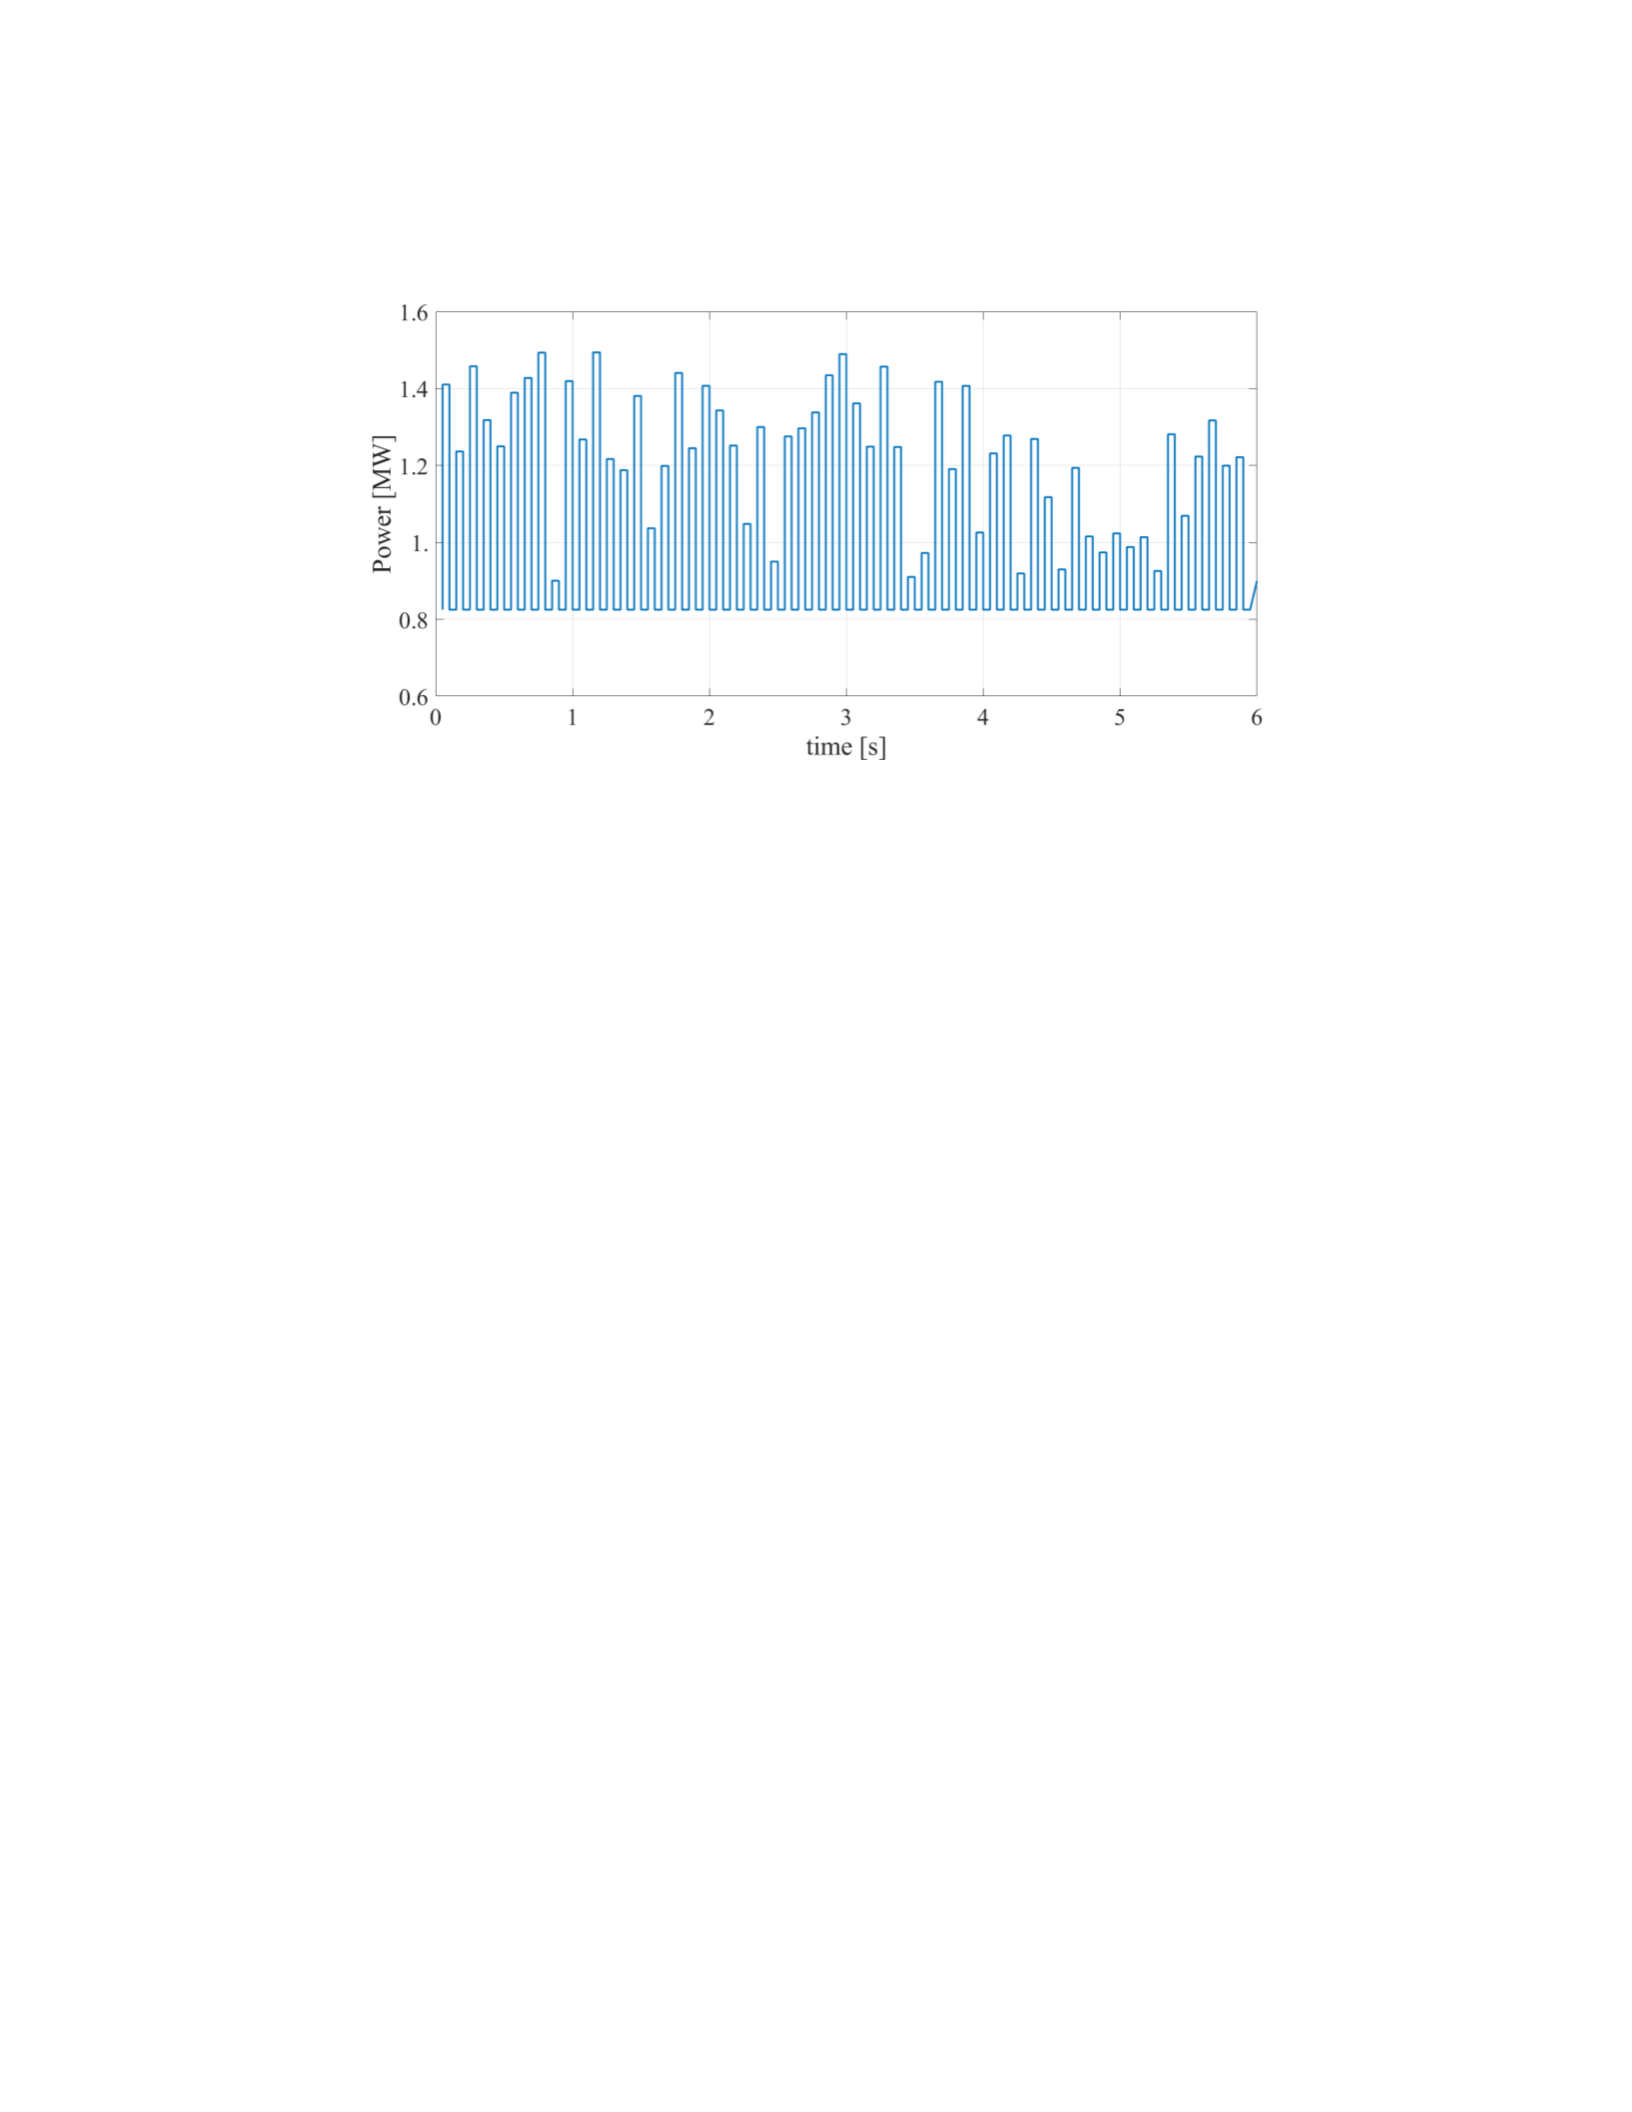
114
shaving and determination of maximum energy demand as in the Radar profile.
Figure 17: Power profile of Electronic Warfare systems (Tavagnutti, Chalfant, Chryssostomidis,
& Hernandez, 2023)

115
Laser Weapon Mission Load : Modeled as an intermittent load profile where the firing
state draws a maximum power demand of 1,200 kW and the non-firing state retains 200
kW of standby power drawn from the power distribution bus, Figure 18. Laser weapon
scenarios incorporate stochastic variability in determining the time spent firing or in
standby, with a maximum beam duration of six seconds and a maximum time between
30 seconds. This scenario accounts for thirty minutes of active charging, consisting of
firing and standby states, followed by forty minutes of ESS recharging. Since the laser
pulls almost entirely from the ESS during a thirty-minute lasing period, the maximum
energy demand for each run depends on the stochastic model of the firing duration.
Figure 18: Laser Gun power profile during 70 minutes of operation time. Enter a 200-second
period. (Tavagnutti, Chalfant, Chryssostomidis, &
Hernandez, 2023)
Combined Mission Load : Modeled as a combination of stochastic load demands of
three Radar weapon elements, two EWs, and one Laser. The maximum energy
116
demand is determined by taking the amount of energy demand at each step of the
lowest level time.
Spinning Reserves : The energy capacity of the ESS is required to provide 2 MW of
continuous power for at least five minutes of ship operation, as assumed for the ship
concept presented by (Tavagnutti, Chalfant, Chryssostomidis, & Hernandez, 2023).
Each of the 125 ESS concepts was evaluated for Energy Storage Flexibility (ESSF)
measured against five operational scenarios. Table 27 identifies the number of concepts with
sufficient power and energy required to meet each scenario. Eight concepts are able to meet all
five operational scenarios. The average ESSF score across the design space was 0.41 and the
average score was 0.40. The design space is generated based on the range of system-level
demands in each element evaluation. The total power demand of bus capacity ranges from 200
kW to 4.4 MW, the demand for energy storage capacity ranges from 817 kW to 2.8 MW, and
the total ESS energy required ranges from 0.18 to 100 kWh. Design 125 concepts
117
space includes architectures that are sized taking into account system cost and affordability to provide
options that are "right-sized" for the requirements of a particular scenario.
Table 27: ESS Design Space Flexibility Results for 125 Total Concepts
3x
Rada
r
1x
Laser
Gun
2x
EW
Spinnin
g
Recom
mendat
ions
Combinatio
n
All
scenari
os pass
Sum
Passing Concept
75 75 64 30 12 8
Failed due to Bus
Capacity
50 0 25 0 75 NA
Failing due to
Energy
Capacity
0 50 25 75 50 NA
Failed because
of Max
Power Rating
0 0 25 50 75 NA
6.4 Interface Control
Interface control is essential for establishing system integration requirements for future
equipment installations in a broader system-of-system architecture. Identifying the right
118
interface requirements, taking into account the physical, logical, and operational requirements
for a particular system, will increase system flexibility by minimizing the cascading effects of
unknown system changes in the future. There are two types of interface requirements documents
that are commonly used:
Interface Control Document: a formal means of assigning, defining, and controlling
interfaces. Document detailed interface design information between systems and sub-
systems for the platform.
Installation Control Drawings : provide ship installation data for future equipment, such
as mission system elements. These documents and drawings define and support the
engineering, installation, and construction of the platform.
For mission systems, Installation Control Documents may be written to establish maximum
physical characteristics, or "not exceeded" values, such as SWAP-C size limitations, location,
and required services of power and energy systems, and auxiliaries. In this case, the Installation
Control Document adds requirements for the capacity of the power generation system, and the
size of the distribution and conversion system in each zone.
Interface Control documents for other ship preparations, such as compartment reservations,
specify the physical and logical requirements of the reserved space on board. These documents
are often associated with a modularity approach, where the physical space and connectivity of
the modules are defined inside the ship to accommodate future theoretical systems that meet the
requirements of those interfaces. This approach determines the location of future load requests
and routes the necessary distributed systems, services, and utilities if needed.

119
Specifically for power and energy systems, an Interface Control Document can be written to
enable Real Options for future upgrades to the P&E system itself. Within the confines of the
P&E system, future requirements may drive the need for additional power generation, integrated
energy storage, and/or expanded distribution element capabilities. Section 6.5 further defines the
Real Options Analysis and provides examples related to options and preparations for future
upgrades to the power distribution system as future unknown loads are realized.
6.5 Real Options Analysis
Real Options Analysis (ROA) is a method of using flexibility in design to maximize the
expected value of a system while minimizing upfront procurement costs and operating lifecycle
and sustainability (O&S) costs. It allows designers to evaluate the uncertainties inherent in
system engineering issues and develop designs or plans that maximize value at specific times in
the system lifecycle, such as at the time of initial delivery, while maintaining the ability to adapt
to unknown requirements in the future. In other words, Real Options allows a design or project
to be ready to change, by incorporating accommodations (preparations) for flexibility. This
allows the system to retain value throughout its life cycle, rather than becoming obsolete in the
face of new requirements.
Real Options Analysis uses a Net Present Value (NPV) financial evaluation to
determine the value of real assets, such as construction projects or alternative investment
opportunities, along with a design decision model to account for the manager's role in the
Determine when to take action to implement design preparation during the system lifecycle.
Where NPV uses deterministic assumptions about cost and profit variables, ROA models
uncertainty in evaluation scenarios and looks for opportunities to use it to
system advantages. (Page J., 2012)

120
NPV analysis converts all cash flows over the life of the system into a common basis in the
present to obtain a single comparable value. This includes all life cycle costs and upfront
investments or construction costs, as well as future profits generated by the system in operations
or financial opportunities. As shown in equation (6), the NPV of future cash flows (Vt) is
determined by applying the discount rate (r) and taking into account the time between the present
and future periods for all cash flows. The discount rate is a value applied to reflect the difference
in the current value of money versus the value of the same amount of money in the future. This
allows decision-makers to recognize the cost impact or benefit of future investments in terms of
the effort spent now. In this type of valuation, the current value of money is greater than the
same amount in the future. In financial terms, the discount rate represents the opportunity cost of
capital, or the potential return on investment based on all other opportunities available to
investors, and is usually set as an industry standard. The project model that produces the naval
power and energy system is subject to the discount rate requirements set by the Office of
Management and Budget (OMB) under the Office of the Executive President. In 2022 the
discount rate is determined to be 0.5% for 30-
121
investment plus year (OMB Circular A-94 Guidelines and Discount Rates for Benefit-Cost
Analysis of Federal Programs, 2022).
NPV = Vt
(1+R)t
(6)
Ship design and acquisition are investments in the form of real assets that are not expected
to generate profits with the standard execution of NPV analysis. To balance current costs with
the value of the system in the ROA evaluation model, a measure of performance (MOP) is
required. For the analysis of power and energy systems, one of the flexibility metrics presented
in the above section is a valid MOP, depending on the scenario of interest. NPV and MOP are
modeled simultaneously in evaluation scenarios that take into account incurred costs and
variable changes that affect performance metrics over time, such as annually over the expected
lifetime of the system. The value of Real Options Analysis comes from the inclusion of
uncertainty in the evaluation scenario.
Uncertainty can be implemented by determining potential disruptions to the system, such as the
exercises shown in Section 5.2, setting minimum and maximum limits and possible uncertainty
parameters, and linking impacts to NPV and MOP variables.
Once the uncertainty parameters are linked, the designer can identify Real Options or
preparations in the design, which are necessary to minimize the risks identified in the baseline
case uncertainty analysis and provide cost-effective options to maximize system performance.
Decision models are then developed to establish the regulatory logic of when actions should be
taken in order to implement options in response to the realization of uncertainty.
6.5.1 Case 5: Analysis of Real Options of Future Integrated Power Systems
122
This case study demonstrates the use of Real Option Analysis of a flexible power
distribution architecture. A basic case and two Real Option alternatives of a notional naval
surface combatant are evaluated with the intent to maximize the platform's mission capabilities
while minimizing upfront procurement costs and O&S lifecycle costs over its expected 40-year
service life. The ROA evaluated the electrical power distribution system for the zonal IFTP
concept, an architectural variant identified in Case 3 that includes a notional energy storage
(ESM) module.
Evaluation Scenario:
Based on the combination of missions performed, operating speed, and other equipment
configurations, the power distribution system will experience various loading conditions.
Typically, distribution systems (as well as power generation systems) are measured based on the
most stressful conditions to ensure adequate capacity and performance in all conditions. This
system model evaluates performance and cost based on the most stressful scenario: the demand
for propulsion (from the PMM) plus the maximum margin electrical load (from the PLM).
Maximum margin electrical load including mission operation demand. While this scenario
requires the highest load demand on electricity
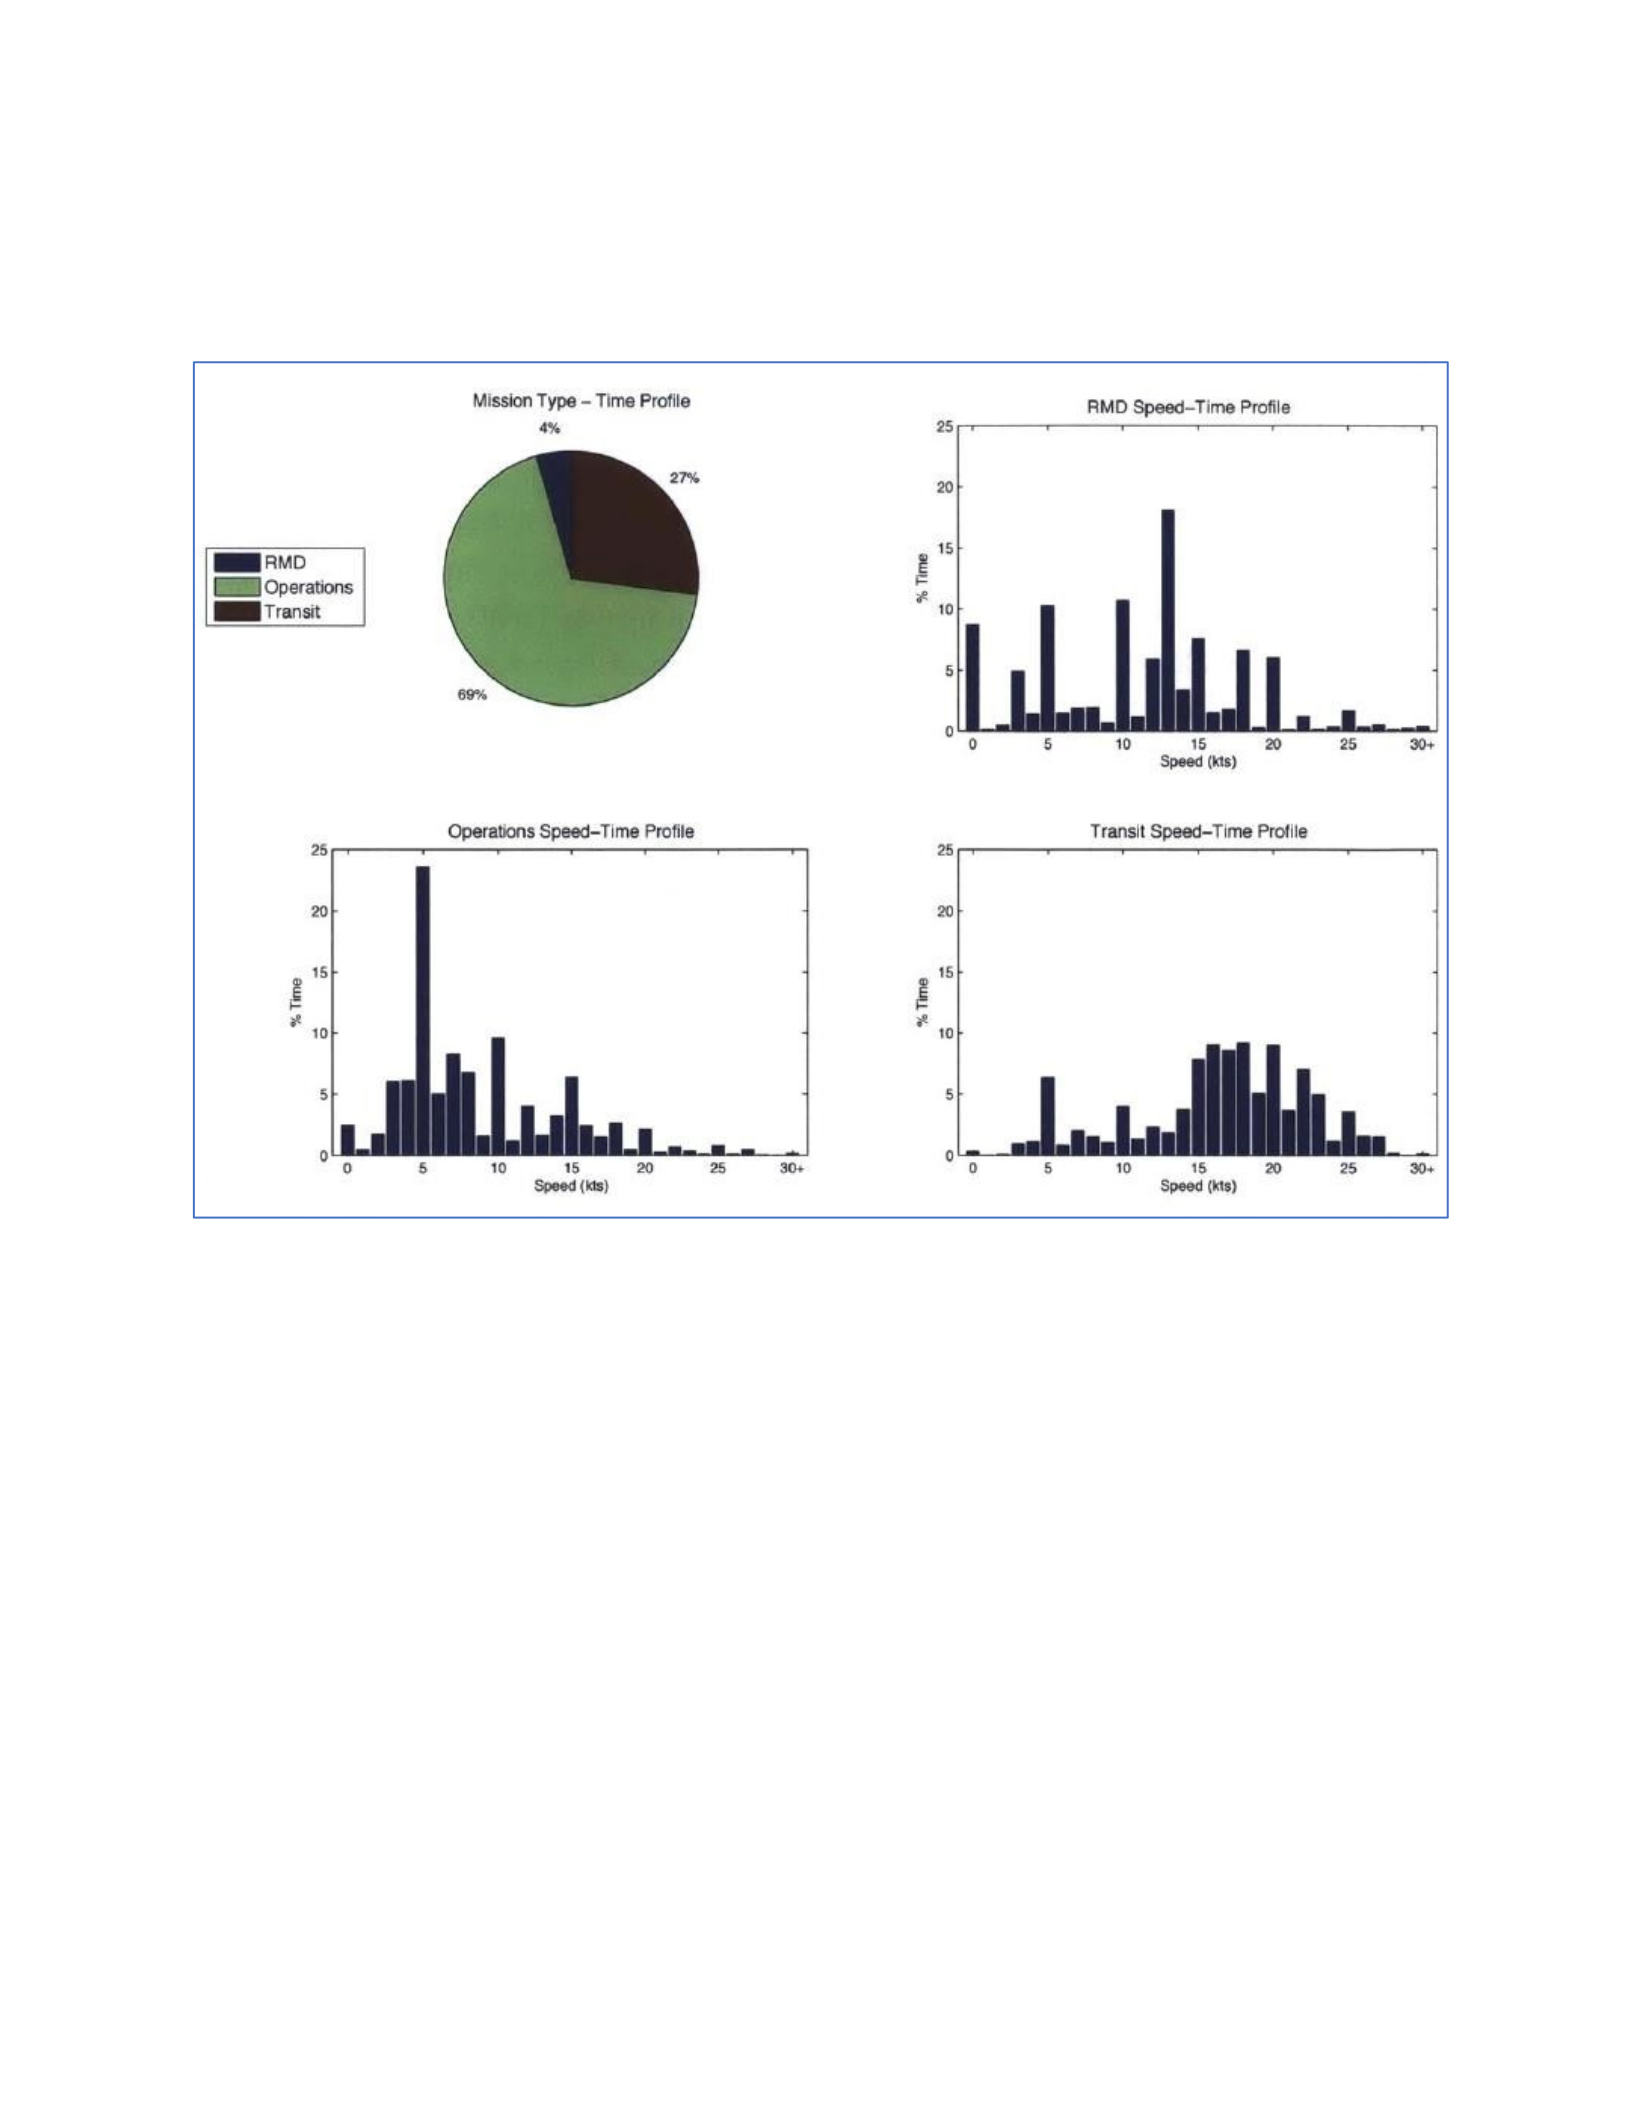
123
distribution system, it only accounts for about 12% of the ship's time at sea for the Navy's
current fleet of Arleigh Burke-class destroyers, as shown in Figure 19 (Anderson, 2013).
Figure 19: DDG-51 Mission Time-Type Operation Profile (Anderson, 2013)
The CONOPS system, modeled as the annual operating conditions of the concept, is based
on a combination of Anderson's (2013) mission speed time profile in Figure 19, and the PMM
plus PLM load set in Table 28. It is assumed that based on the load demands of the ship and
mission service systems, and the capabilities inherent in the IPS architecture, that the speed of
mission operations is allowed to decrease over the life of the vessel, in order to discharge the
propulsion power for the vessel's load demands if needed.
124
Table 28: CONOPS Condition Loading Profile
Hours % PMM (MW) PLM (MW)
Low-Speed Missions 0.57 15 20.16 (basis) / Uncertainty
of Stochastic future load
High-Speed Missions 0.12 60 20.16 (basic) / Stochastic
Uncertainty of future
burdens
Transit 0.27 18 3
Limited Maneuvers
Doctrine (RMD)
0.4 5 3
125
To determine the operational scenario on the delivery of the system (year 0), the initial
maximum margin electrical load was assumed to be 18.8 MW, based on the 85% efficiency
factor applied to the maximum distribution capacity of the current DDG 51-class destroyers,
plus a subset of the mission system equipment load of the ESRDC ship concept (Smart, et al.,
2017), as shown in Table 29.A 2 0 % l i f e t i m e a l l o w a n c e i s a p p l i e d t o n o n -
m i s s i o n s y s t e m l o a d s , a s s u m i n g a 4 0 - y e a r l i f e t i m e , r e s u l t i n g i n a n
E O S L m a x i m u m m a r g i n e l e c t r i c a l l o a d o f 2 0 . 1 6 M W , w h i c h i s u s e d
t o m e a s u r e t h e P C M w i t h i n t h e z o n e . L o a d g r o w t h i s a s s u m e d t o b e
r e a l i z e d i n 4 - y e a r i n c r e m e n t s ; T h u s , i n y e a r 4 t h e l o a d d e m a n d i s
18,94 MW, in year 8 the load demand is 19,07 MW, and so on.
Table 29: ESRDC 10,000 ton Combat Power Condition Mission System Ship Concept (Smart, et al.,
2017)
Maximum Margin Electrical Load in Year 0 (MW
)
Non-mission system load 6.8
Persenjataan
Active Rejection System 2.4
Command and Surveillance
Multi-Function Phased Array Radar 5
Integrated Top Side (InTop), including Surface Electronic
Warfare
Improvement Program (SEWIP) and communication
4
126
Hull Mounted Sonar , Crane Array Sonar 0.45
Total Ship Computing Environment (Integrated weapons,
sensors,
engine and navigation control system)
0.15
Vehicle
Helikopter/UAV 0
Small Boat / USV 0
Entire 18.8
Basic Architecture:
The basic architecture consists of the following modules:
Motor Propulsion Module (PMM): 2x 36 Permanent Magnet Motor.
Power Generation Modules (PGMs): 2x Rolls Royce MT-30 Large Gas Turbine
Generators, each with a capacity of 36 MW, and 2x Rolls Royce MT-5 Secondary Gas
Turbine Generators, each with a capacity of 5 MW, for a total of 82 MW of installed
power plants.
Power Load Module (PLM): propulsion and mission load demands, as identified in the
evaluation scenario, plus unknown future loads as identified below, in the Uncertainty
section.
Power Distribution Module (PDM): mainly electrical cables, sized to support
maximum distribution capacity. This capacity remains constant in the base project
model of 20.16 MW, based on PLM max margined electricity load. This assumption is

127
based on the difficulty in sizing ship cables once integrated, requiring wholesale
removal and replacement, and the complexity in modeling less significant cable
modifications between zone electrical loads.

128
Energy Storage Module (ESM): lithium-ion-based energy storage modules, sized for
specific mission load profiles.
Power Control Module (PCON): assumed to be designed alongside the base model
with preparation to support maximum system capability, not modeled in this case.
Power Conversion Module (PCM): based on the modified Zonal IFTP concept in Case
3, where the PCM-1A is primarily a power converter, with a power rating of 1MW. The
PCM-2A receives power from the PCM-1A and functions as an Integrated Power Node
Center (IPNC), to provide various types of low-voltage output power (Doerry, 2008).
The PCM-2A is a transformer rectifier and is assumed to have a rating of up to 500kW.
In addition to NGIPS-based PCM, the casing model uses a notional PCM-X and an ESM
converter to account for the demands of unknown future mission systems. The PCM-X is
assumed to have a 500kW rating and the ESM interface is assumed to have a 500kW
charging converter for every 1MW of mission load output.
The number of PCM-1A and PCM-2As required per zone is based on
maximum margin electrical load at the end of the ship's life (including 20% SLA), assuming
the ability to distribute a quarter of the total load in a given zone. It is then assumed that a
completely redundant set of PCMs is required in each zone. The PCM-X and ESM
interfaces are directly sized for the required mission load, with no redundancy or lifetime
allowance required.
Table 30 identifies the PCM rating assumptions, as well as the cost and
volumetric criteria for the ROA decision model. The fees for each PCM are notional and
do not represent the actual Navy system. Lithium-ion ESM assumes cost
$345/kWh, based on the 'National Renewable Energy Laboratory (NREL) Cost 2021
129
Projections for Utility-Scale Battery Storage' (Cole, Frazier, & Augustine, 2021)
Table 30: Asumsi PCM
Function Rating Cost Volume (m3)
PCM-1A Converter 1000 kW 1,200,000 40
PCM-2A Transform-Repair 500 kW 340,000 18
PCM-X Converter/Trafo 500 kW 1,200,000 12
ESM InterfaceConverter 500 kW $1,200,000+
$345/kWh
450 kWhr/m3
Ship Integration Interface: as the PDM size assumption, the volumetric capacity of the
ship concept dedicated to the power distribution system is measured for the maximum
distribution capacity, reflected in the number and type of PCM required, and kept
constant. Any future PLM that requires the support of an electrical distribution system
can only be activated if adequate ship compartments (volumes) are provided for the
required PCM equipment.
Performance:
The performance of the power distribution system in this model is represented in terms of
Flexible Power Capacity (FPC, equation 1). FPC is calculated for each step of time (years) and
the overall measure of performance for power flexibility is taken as a weighted average of the
130
existing conditions in 1-40 years. Weighting is based on notional temporal priority, where mid-
life flexibility of the system is prioritized over the beginning and end of life. In this case, the
desire to improve operational performance during the second half of the system's life is higher
than immediately after the delivery of the system (requiring taking new mission system assets
offline) and at the end of the service life (limited operational value based on hull life).
The amount of power capacity that can be distributed is based on the number of power
conversion modules of each type and the capacity of the PDM in advance. In this model, the
distributable power demand is initially based on the Navy's standard design practice of the
Service Life Allowance. The PCM and PDM architectures of the base case are sized to meet the
deterministic predictions of end-of-life condition requirements, based on projected SLA
requests, so that the Flexible Power Capacity performance metric is a positive value near zero.
When uncertainty is introduced in the ROA model, the performance value will reflect the impact
of the magnitude of the change in actual demands and when in the lifecycle of their systems is
realized.
NPV:
Net Present Value is calculated in this model based on Basic Construction Costs (BCC) and
Operating and Sustainability costs. BCC covers the material, labor, and overhead costs
associated with purchasing, constructing, installing, and activating a vessel. In this model, the
BCC cost relationship is developed using the 'MIT 2N Ship Cost Model' (2016), with input from
the ESRDC ship concept (Smart, et al., 2017) as a replacement platform and the cost of the
power distribution system module as defined in the basic architecture. To determine the impact
of implementing Real Options, the BCC cost model was adapted to identify the cost of additional
manageable vessel volume and the cost of the required PDM equipment.
131
Table 31: Cost Parameters
Cost Parameters Value
BCC ($M) $1,003+(PCM Fee)+(ESM Fee)+(Fee Volume)+(PDM
Fee)
Volume cost ($M/m3) $0,031
PDM Fee ($M) ((delta MW)/0.85PF/13800V)/800A*$250/ft*775ft
O&S Fees ($M) $200+($3)*(3000Hours)/(6.8*(Fuel Consumption
Rate)/1000)
O&S costs take into account the annual costs of personnel, operations, maintenance, energy,
replenishment, and support activities. This model has isolated the annual energy impact
associated with the ability of the power distribution system architecture to meet the required
PMM and PLM power load demands. This requires characterization of the interface of the power
distribution system with the PGM, including fuel consumption and generator lineup. In
particular, the level of fuel consumption depends on the load demand of PLM plus PMM, the
selection of the generator lineup, and the efficiency of the generator under those operating
conditions. At each annual time step, the fuel consumption level is determined by pairing the
appropriate PGM range, Table 32, in each operating condition specified in CONOPS, Table 28.
Fuel consumption
132
the next level is adjusted to account for notional PGM efficiency based on the generator load
level, Figure 20 (Smart, et al., 2017).
Table 32: Power Plant Lineup
PGM Composition MW online Fuel Consumption
(ltons/hour)
MT5 5 1.36
2x MT5 10 2.73
MT5 + MT30 41 8.70
2xMT5 + MT30 46 10.06
2x MT30 72 14.67
MT5 + 2x MT30 77 16.03
2xMT5 + 2xMT30 82 17.39
Figure 20: Efficiency of notional generators as a function of power levels (Smart, et al., 2017)
133
Uncertainty:
In evaluation scenarios, a number of disruptions can affect performance measures and NPV.
For this case, the main source of uncertainty is modeled based on long-term disruption to
"change in mission system load", with a sub-type of "increased load demand", as identified in
Table 4. To account for future variations in mission system loads, the probability distribution
function was developed from a combination of potential high-energy weapons and sensors, as
identified by ESRDC (Smart, et al., 2017). To simulate the normal ship placement, maintenance,
and upgrade cycles, the system model assumes that the upgrade of the mission system occurs
gradually over and over again.
Therefore, the probability that an increase in the load of the mission system is realized in a
given year is modeled as a probability of 10%.
In addition to large fluctuations in the electrical load demand of the mission system itself,
secondary uncertainty parameters for the "new type of load (pulse load, ramp rate)" sub-type
interference are included in the model to account for the portion of the future mission system
134
loads that require energy storage, and a sub-type of "secondary impact realized in auxiliary
systems" to account for future mission system load efficiency. This secondary
The uncertainty parameter takes into account the impact of the ship's service distribution system
associated with auxiliary and supporting equipment, such as thermal management and control
equipment.
The uncertainty input factor is shown in Table 33.
Table 33: Mission system load uncertainty input factors
Variable Uncertainty
Probability of Schedule
Increase
10%
Realized Request (Mission
Load)
LOGNORMAL PDF
Mission System Load
Efficiency
30-70%
Part of the new Mission
Payload
Requires ESM
0-100%
Probability Distribution
Log-Normal Distribution
mean 1.34
Standard deviation 1.7
135
Excel Result Model:
Given that the Mission System Load is the highest source of uncertainty, a decision model
was developed to account for the variability of the electrical load demand of the mission system
elements and the necessary additional equipment, to ensure the performance of the distribution
system over the 40-year service life of the platform. Decision models are also needed to
minimize the cost impact of NPV required to provide performance flexibility.
In the base model, the expected mission system load is specified to be 12 MW, served by 24
dedicated 500kW PCM-X. The Navy's standard 20% electrical power SLA is applied to the
Primary and Secondary power distribution element sizes, PCM-1A and PCM 2A, but no design
considerations are included for mission system elements that require dedicated PCM-X utility.
In standard practice, the ability to add the necessary capabilities in the future will depend on a
combination of separate SLA categories for vessel displacement, KG, and manageable areas, so
a custom PCM-X can be added. Once the specific SLA capacity of other non-electrical systems
has been consumed, the standard basic approach will require the one-for-one removal of existing
equipment to be replaced with a new desired element or demand load.
The excel decision model is built to support the evaluation of Real Options that takes into
account the uncertainty of the mission system load and provides a cost-effective means to
improve the future load capability of the mission system. The decision criteria in the model are
structured around the identified uncertainties: the schedule of the increase in the load of the
mission system, the magnitude of the increase in the load of the mission system, the efficiency
of the new load, and the type of load. If the conditions to meet the identified decision criteria are
realized, design flexibility options can be implemented.
136
Table 34: Decision Criteria
Sources of Mission
System Load
Uncertainty
Characterizat
ion of
Uncertainty
Decision Criteria System Impact
Upgrade Schedule
Event
10% chance in each
year
New mission system
Load request
Quantity and types
PCM, dan ESM
Amount of Load Log-Normal PDF Mission system load
Increase
Quantity and types
PCM, dan ESM
Load Efficiency 30%-70% Additional support
Equipment required
Number of PCM-1A
and
PCM-2A
Load Type 0%-100% of the new
load that requires ESM
Energy storage
module required
kWh ESM capacity
and charging amount
Converter
The flexibility options (Real Options) evaluated in this model include the option to install
additional PCM-X, PCM-1A, PCM-2A, ESM Charging Converters, and ESM battery modules.
The preparations required to activate this option are the provision of a dedicated electrical
distribution system compartment (volume) on board, a maximum rating of PDM that is initially
too large, and the ability of IPS to discharge PMM power for the load demand of the mission
system. Capacity limitations for flexibility options are based on this preparation and are shown
in Table 35.
Table 35: Capacity Limitations of Flexibility Options
137
Capacity Type Flexibility Limits Value
Max PLM
Power
(MW)
Minimize the specific PMM Power required 72 MW (with minimum PMM
10 MW requirement)
Volume (m3) Adjustable space allocated for electricity
Distribution on ship shipping
50% improvement from base
Max PDM
Rating
(MW)
The number/size of cables (etc.) installed on
the vessel
Delivery
72 MW (a 350% increase
from
basic request)
Basic Case (With and Without Uncertainty):
The basic case is a deterministic model that represents a standard Navy design approach in
which propulsion, ship service, and mission system load are specified for the initial system
delivery conditions, and all desired future growth is accounted for with a standard 20% SLA. In
this way, the power distribution system is designed for the number of PCMs, PDMs, and in this
case there is no accommodation for ESM. The performance NPV and cost results from the base
case assume the results are exactly as predicted and indicate a cost-effective way to deliver the
required performance. However, the final outcome of the next 40 years is not easily predicted
and risks being affected by uncertainty.
The static base case was developed as an initial project model, without uncertainty, to
provide a deterministic analysis of the notional power distribution system. It is used to
investigate the direct relationship between input variables, model assumptions and constants,
and derived parameters. It assumes that the power distribution system for IPS electric boats

138
designed for a 40-year service life is based on the propulsion power required for sustained
speed,
139
plus the ship's service power and mission system load requirements as described in the
Evaluation Scenario. The deterministic result is a system with a FPC Power Capacity Flexibility
performance value = 0.055 with an NPV cost of $9.07B. Of this $9.07 billion, BCC is
responsible for
$1.07 billion, and $71 million of BCC is attributed to the distribution system (about 7%).
Table 36: Fixed Input Parameters
Demand projections
Demand in year 1 (MW) (maximum
margin
power)
8
40-Year Power Demand Growth 20%
Load X Projected Mission (MW) 12.0
Future ESM Load (kWh) 0
Cost Parameters
Basic Construction Costs ($M) $1,003+(PCM Fee)+(ESM Fee)+(Vol Fee)+
(Fee
PDM)
Ship area addition fee ($/m3) USD $0,031
Delta of additional cable charges ($M) ((delta
MW)/0.85PF/13800V)/800A*$250/ft*775ft
O&S Fees ($M) 200+($3)*(3000Hours)/(6.8*(Fuel Consumption
Tariffs)/1000)
140
Performance Parameters
Propulsion Power (Continuous Speed
30kt)
(MW)
60
Total installed power (MW) 82
Types of Architecture IP
Until MVAC
DST compartment (m3) 2,165
PCM1 – (kW DC:DC) 1000
PCM2 - (kW AC:DC) 500
PCMX –kW 500
kW Energy Storage Module 500
PDM (cable, junction, other) rating
(MW)
20.16
NPV
Time horizon (years) 40
Discount rate 0.5%
The basic case modeled with uncertainty supports the stochastic analysis of the value of
the power distribution system. The primary and secondary uncertainty parameters identified in
the Uncertainty section, above, reveal the risks inherent in static-deterministic models.
Figure 21 shows the cumulative distribution function (CDF) for Flexible Power Capacity, given
the uncertainty in future mission system loads, and Figure 22 shows the associated NPV. In each
cumulative distribution function, the red line indicates a deterministic case. In both aspects of

141
the evaluation, the static case is in the favorable region of the possible outcome, on the right side
of the CDF curve. Most of the areas below the left curve of the deterministic line represent
uncertainty structured as risk. In other words, if a deterministic case is used to design a power
distribution system, there is a high chance that the system will have insufficient capacity.
142
Figure 21: Performance – Flexible Power Capacity (FPC) of CDF for a base case with
uncertainty
Basic Case with Uncertainty - Flexible Power Capacity Model Performance
Cumulative distirbution function
100. 0%
90.0%
80.0%
70.0%
60.0%
50.0%
40.0%
30.0%
20.0%
10.0%
0. 0%
-2.5
Policies with
Uncertainty
Deterministic basis
-
2.0
-
1.5
-
1.0
-
0.5
0.
0
0.
5
Static Base Case with Uncertainty - Flexible Power Capacity (FPC) Performance
Probability that the realization value is less than
the target value
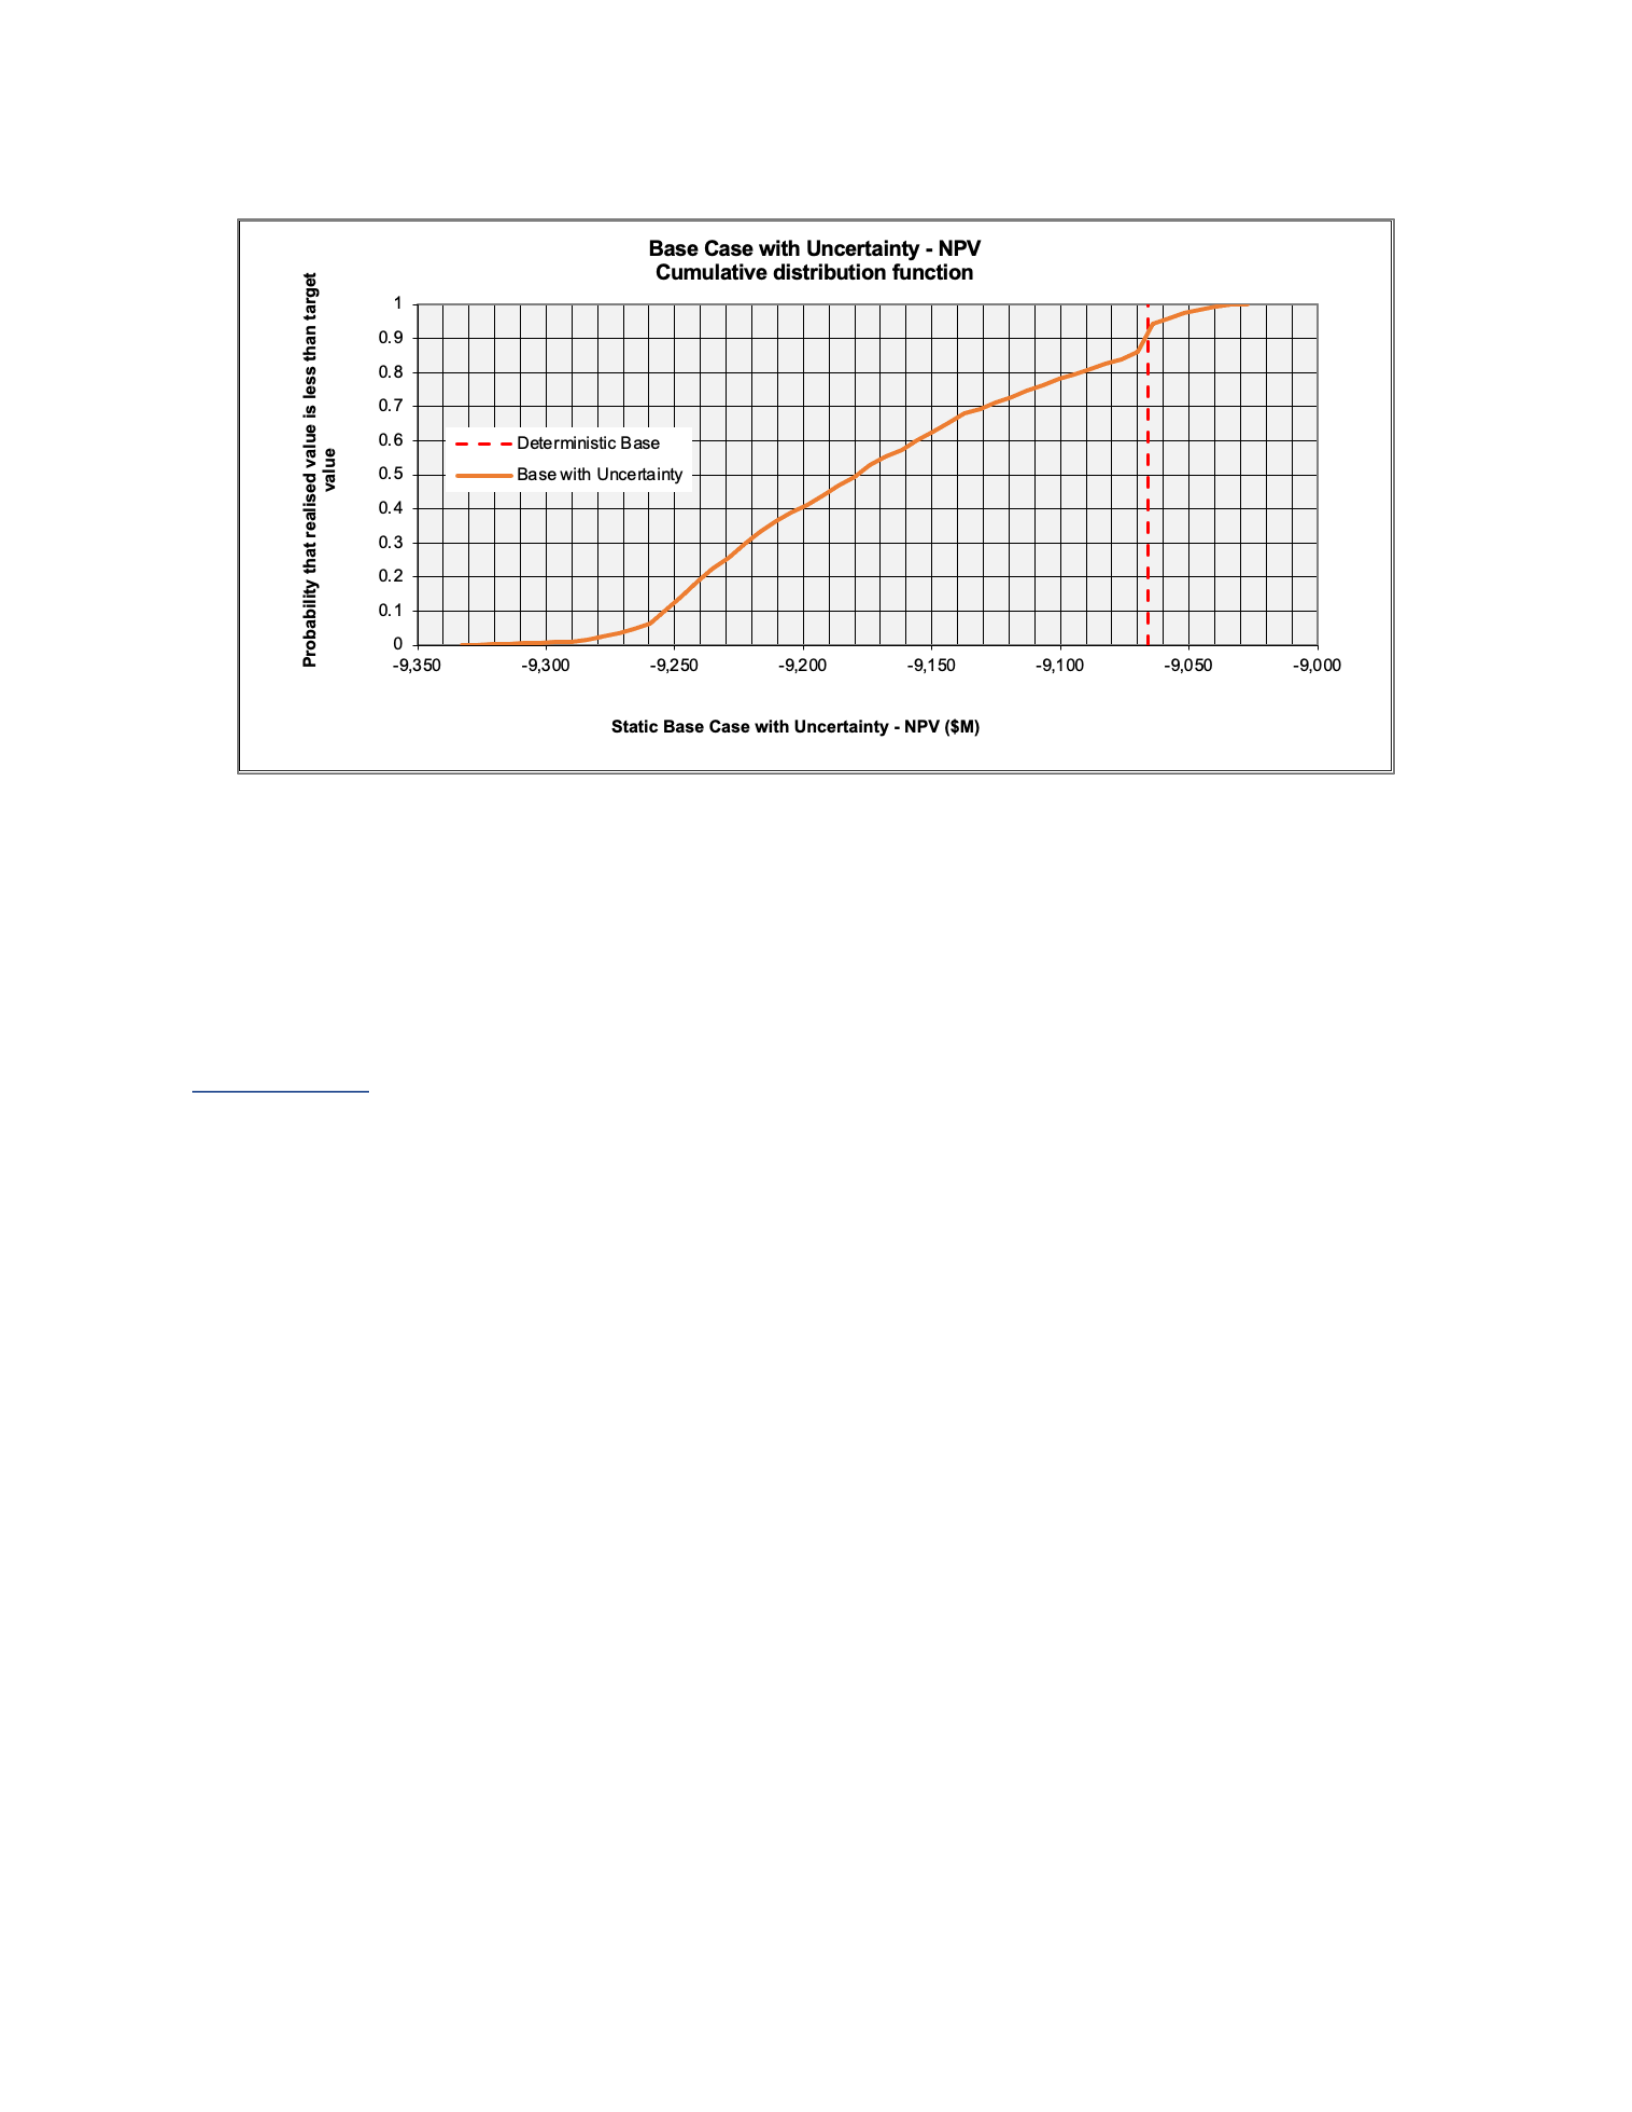
143
Figure 22: CDF net present value for the base case of a power distribution system with
uncertainty
Real Options:
In order to minimize the risks identified in the baseline case uncertainty analysis and
provide cost-effective options to improve the performance of the power distribution system, an
evaluation of flexible design options is conducted. Focusing on the uncertainty of the load of the
mission system, the Real Options model was developed to identify the preparations needed to
enable future growth in the capacity of the power distribution system, while minimizing the
impact on NPV costs.
In the case of the Real Option, the vessel platform includes the preparation of flexibility on
the initial shipment to provide additional unused volumes dedicated to the growth of the
electricity distribution system and
upgraded power distribution modules, including cables sized for future electrical loads greater
than the PLM load of initial mission conditions. The cost to include this upfront preparation is
144
It is taken into account in the basic construction cost in year zero. Otherwise, in the initial
system delivery, the number and type of PCM are the same as in the basic case.
As in the basic case with uncertainty, the source of the load uncertainty of the mission
system is modeled to show the variability in the demand for the load of power distribution, and
its associated impact on the derived parameters. However, unlike the base case, the Real Options
case with flexibility is enabled by the decision model to determine the time, magnitude, and
variation of the capacity of additional PCM and ESM modules to be added to the system.
The decision model evaluates the actual electrical load demand against capacity over the
previous 4 periods to determine whether the available flexibility options should be realized. The
decision to expand the system by adding PCM and ESM depends on the capacity of the
remaining initial preparation: volume, capacity of the Power Distribution Module and capacity
of the Drainable Power Generation Module from propulsion. Two Real Options cases are
presented below to evaluate the impact of decision module variables on capacity expansion
rates. Real Option 1 is intended to provide adequate power capacity as demand increases, while
minimizing the cost impact by installing only the desired number of PCMs and ESMs to match
current demand. Real Option 2 is intended to maximize the value of system performance by
anticipating trends in increasing mission loads and taking advantage of the availability of
selected vessels to install additional capacity (double the current increase in demand loads). In
both cases, the capacity limit is kept constant as shown in Table 35. The cumulative distribution
function of performance and NPV for this Real Options case, compared to the base case, is
shown below in Figure 23 and Figure 24.
Real Option Implementation - Performance Cumulative distribution
function Flexible Power Capacity
1
0.
9
0.
8
0.
7
0.
6
0.
5
0.
4
Deterministic Basic
Base with Real
Option Uncertainty
1
Real Option 2
0. 3
0. 2
0. 1
0
-2.5-2.0-1.5-1.0-0.50. 0 0.
5
1.
0
1.
5
Real Option Implementation - Performance Flexible Power Capacity (FPC)
Probability that the realization value is less than
the target value

145
Figure 23: Performance – CDF Flexible Power Capacity (FPC) for Real Options
The cumulative distribution function of the performance model shows the maximum FPC
value that each architecture can achieve. The deterministic base case shows a reference point
for the initial architecture assuming there is no uncertainty for future growth in the mission
system load beyond the planned 20% SLA. The basic case with uncertainty suggests that the
likelihood of
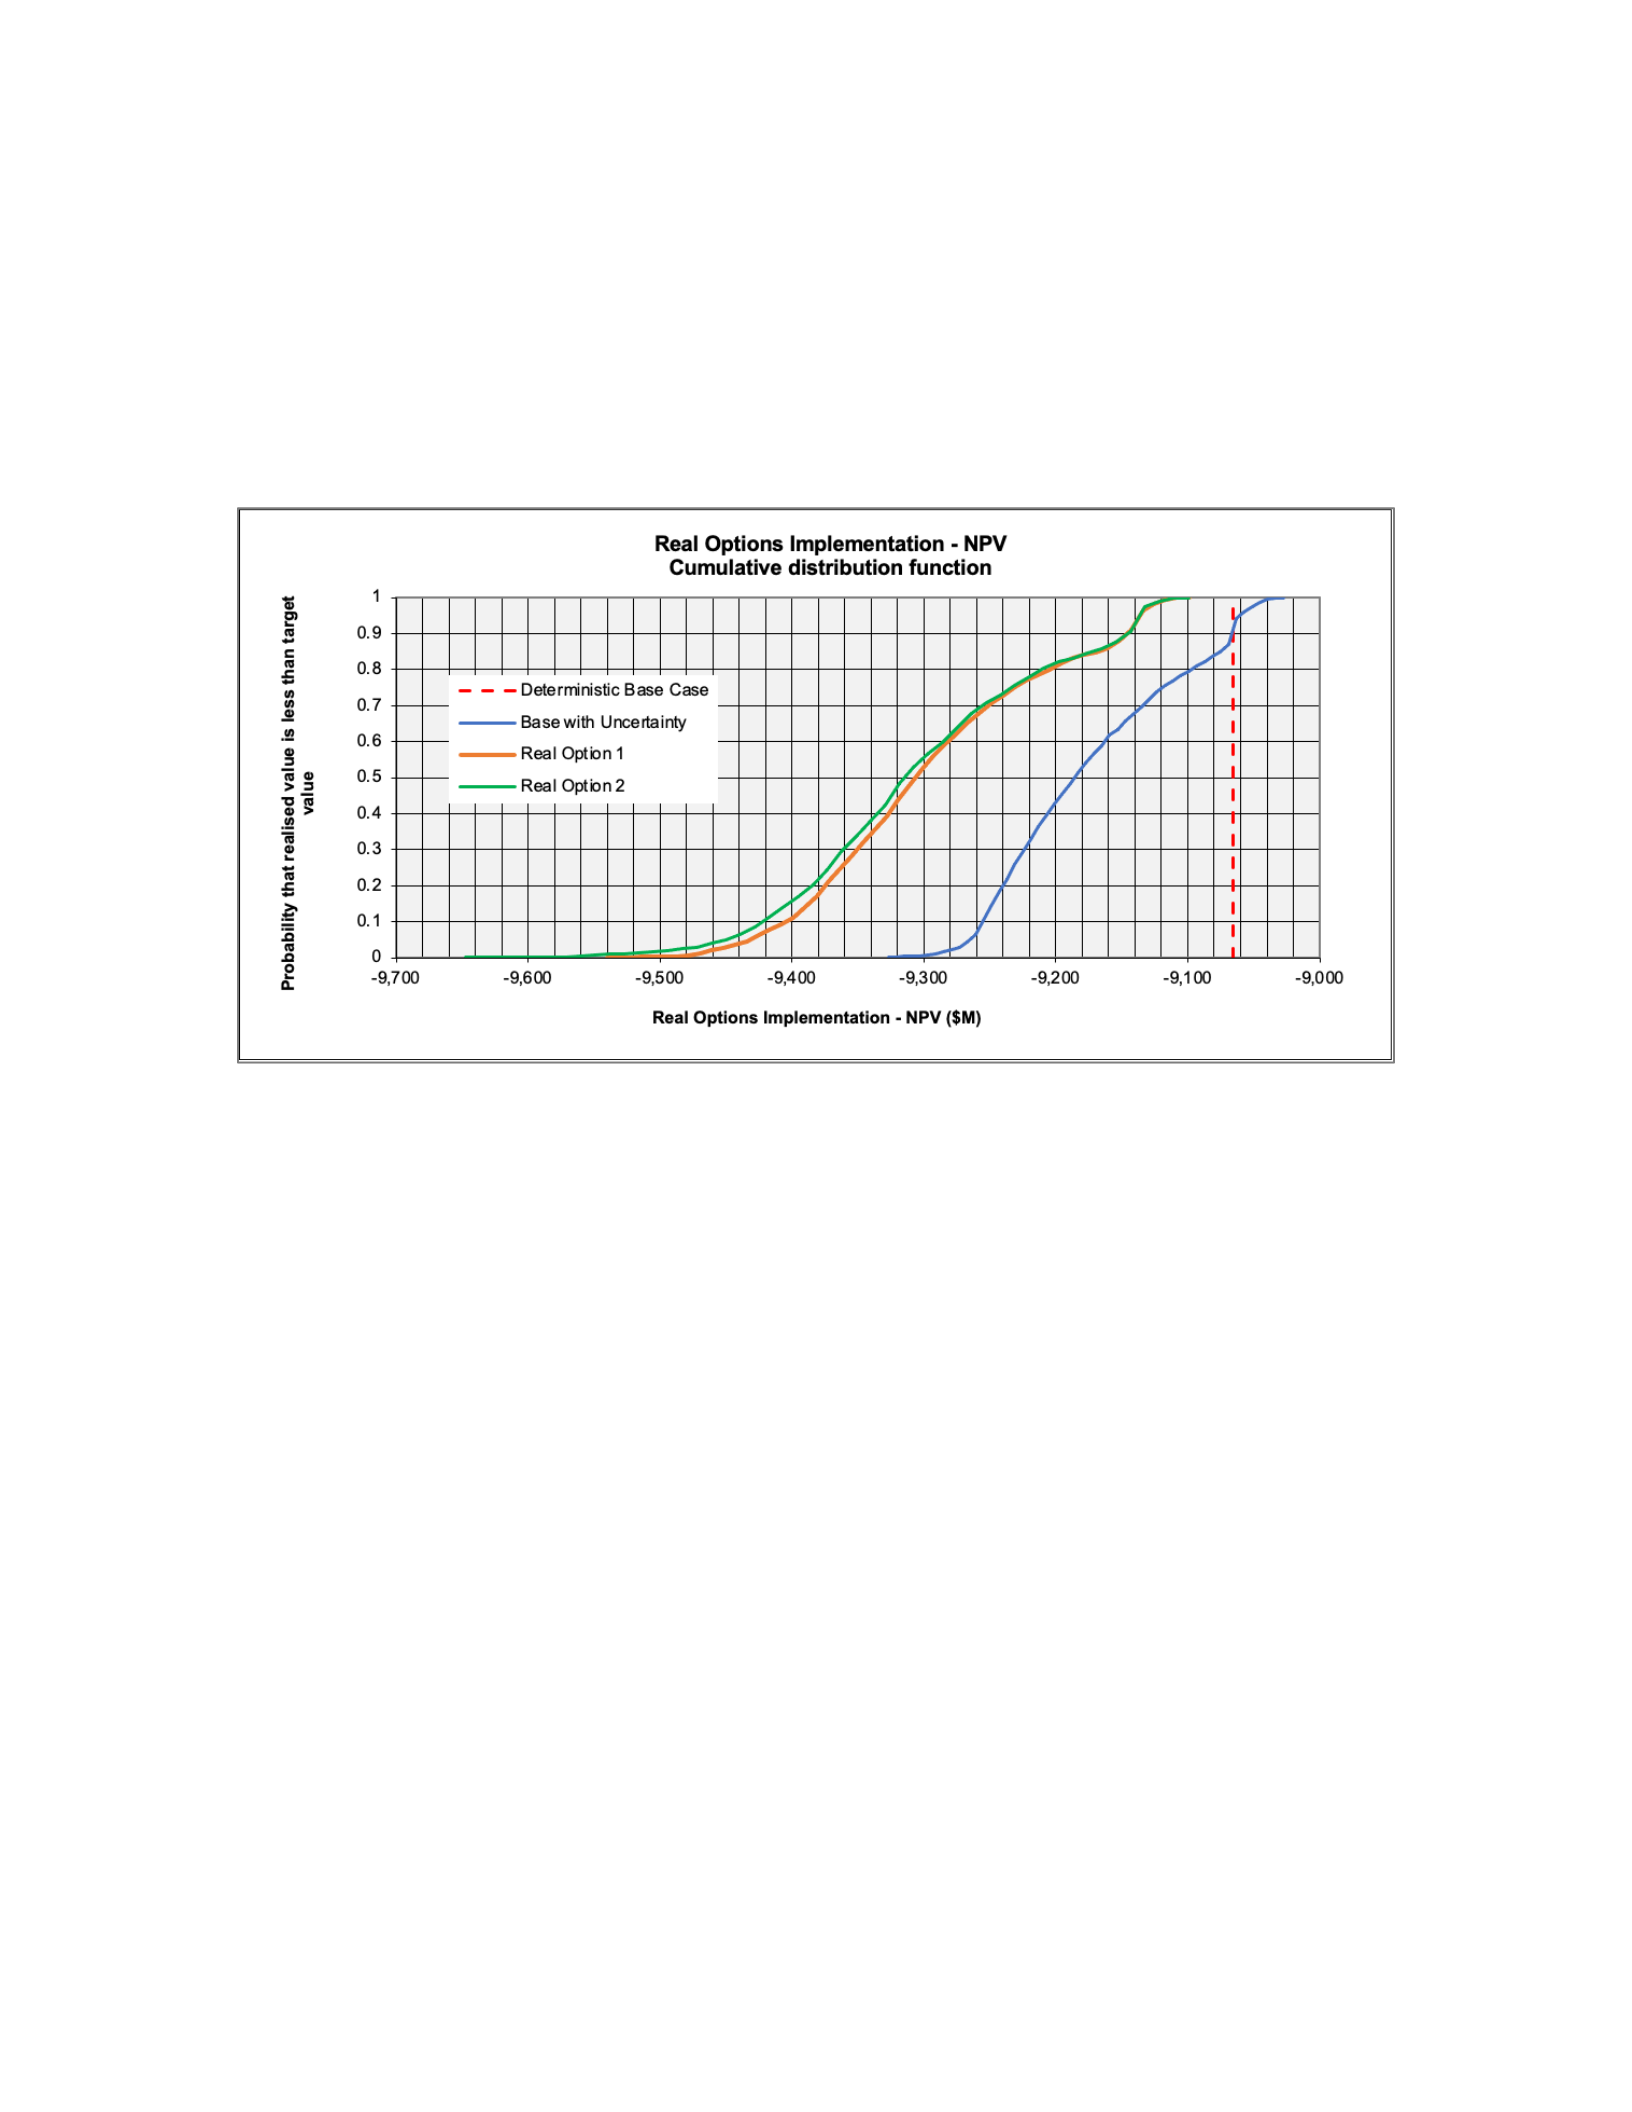
146
poor performance and significant loss of system value. The case of real options uses preparation
in design to allow decision-makers to respond to uncertainty when it is realized and minimize
the possibility of poor performance. This is represented by a "shift" of the CDF curve to the
right, and an increase in the maximum FPC outside the deterministic case.
Figure 24: Net present value of CDF for Real Option power distribution system
The cumulative distribution function of the NPV model shows the potential lifecycle
cost of each architecture, compared to the deterministic base case. The static base case is shown
as a lower cost option, however, we know from the performance model that it is not possible to
provide adequate system value over time because the disruption in the load requirement is
realized, as represented by the base case with uncertainty. The case of real options requires
additional acquisition costs upfront to include preparation in the design that allows decision-
makers to respond to future uncertainties. It is important to note that while NPV reflects the
total life cycle cost, the preparation cost for Real Option Case 2 is only $70 million (6.5%)
greater than the base case BCC. Although this is a relatively small contribution to the overall
147
NPV cost, which is greater than $9 billion, the power distribution system itself is only 6.7% of
the ship's total BCC.
Discussion:
This Real Options Analysis model shows the value of flexible design options in terms of
Flexible Power Capacity and NPV performance. Designing a distribution architecture to
accommodate modular power conversion modules with a wide range of voltages and capacities,
allowing the option to add PCM and ESM as the load demands of unknown mission systems
increase in the future, and the decision model criteria are met. The preparations required to
activate this option are the provision of a dedicated electrical distribution system compartment
(volume) on board, a maximum rating of PDM that is initially too large, and the ability of IPS to
discharge PMM power for the load demand of the mission system. Capacity limitations for
flexibility options are based on this preparation. In the exploration of design space, variations in

148
Preparation variables and modeling of additional uncertainty parameters will provide designers
with insight into the feasibility and dominance of alternative power and energy system
architectures.
Results from the two Real Option cases show that both flexible architectures will improve
system performance over the base case, with Real Option 2 providing a 65% improvement over
the base case, and positive power flexibility to accommodate future high-energy mission system
loads. While the distribution system did not generate the gains to counter the upfront costs and
annual expenses identified in the NPV analysis, the project results showed the feasibility of
achieving the desired performance capabilities with a 6.5% increase in initial capital
expenditures and a 1.4% increase over the life of the system. These results demonstrate the
ability to achieve significant system performance improvements at relatively low system costs
through the implementation of flexible design options.
7Conclusion
This thesis presents a framework for outlining ility-based requirements into metrics to
identify the dominant architecture in the early-stage design trading space. Ilities are defined as
emerging system properties that affect the system's ability to retain value over time.
Ilities are not a primary functional requirement, as defined in the Initial Capability Document or
the Capability Development Document that defines the system's objectives, but rather attributes
used to measure the system's ability to respond to change. Research from a robust literature
review of these system systems, their relationships, and methods for distinguishing between
preferred solutions in the design trade space was used to develop a hierarchy of "ility"
relationships for naval power and energy systems.

149
The framework for design space exploration considers the physical, logical, and operational
aspects of architecture to produce a set of disruptions that are likely to impact
the ability of the system to retain value throughout its life cycle. Disruption is a mechanism or
influence on a system that requires change. The thesis focuses on the application of the
framework for the design of multidisciplinary naval power and energy systems, which is
responsible for the flow of energy across mechanical, electrical, thermal, and signal domains.
For specific interests, a comprehensive set of potential disturbances affecting emerging
system properties should be identified and correlated with preparation in design. A viable
solution design space should be filled with options that meet functional and ility requirements,
based on the initial identification of design preparation. This preparation can be broken down
into its basic attributes in the physical, logical, and operational appearance of the system. Finally,
design metrics to measure the value of a system under the influence of changes caused by a
given perturbation can be generated by linking independent and dependent variables to the
identified system attributes.
This thesis implements a framework for developing a measure of flexibility of power and
energy systems; This specific ility is selected based on the frequency of its occurrence in

150
a literature review and interest in the wider naval design community. Flexibility is defined as the
ability of a system to accommodate changes in response to disruptions in requirements. For
naval power and energy systems, flexibility is measured within system boundaries, in response
to interference from new and changing loads requiring power or changes to energy flow sources.
Four case studies were conducted to develop metrics for Flexible Power Capacity, Removable
Power Flexibility, Distributable Power Flexibility, and Energy Storage Flexibility. The fifth case
presents the application of Real Options Analysis to balance system performance and cost for the
"right size" of the P&E system on the initial delivery with the inclusion of preparation in the
design to react to future uncertainties.
The maturation of development mission system technology with new and increasing demand
for electrical power drives requirements for emerging properties, beyond typical functional
requirements. The U.S. Navy's surface fleet currently faces challenges related to the pace of
technological change and the uncertainty of future combat systems, and significant investment
costs to design and build a new class of ships. Uncertainty affects the system's ability to maintain
mission relevance affordably in an evolving operational context. Affordability constraints in the
Navy's acquisition environment, and the timeline for designing new and modified classes of
ships, emphasized the need to make informed decisions in early-stage design. This work is
intended to present a repeatable process for developing metrics that can be integrated in early-
stage design tools to create and evaluate naval power and energy systems. The application of
traditional and new methods of determining metrics, and implementation in design tools such as
Smart Ship System Design (S3D), will allow system architects to quickly assess a large number
of potential solutions and quickly characterize the cost versus capability sacrifice of discrete
architectural features.

151
The views expressed here are the personal opinions of the author and are not necessarily the
official views of the Department of Defense or any military department.
7.1 Future Jobs
This research has identified several opportunities for further action in the development of
ility-based design requirements standards and further application of the design framework. A
deeper dive into the Department of Defense's requirements and acquisition process can identify
means to directly link ilities to threshold requirements and objective capabilities and bring
greater attention to their value in the programmatic requirements and decision-making and
requirements communities.
The design framework should be further implemented in other technical domains, beyond
power and energy systems, and in the application of additional non-functional requirements, to
better understand trends in the exploration of design spaces and the relationships between areas
of interest.

152
The Navy and the academic community should strive to validate and implement the metrics
presented here for power and energy system flexibility in the Smart Ship System Design (S3D)
program and integrate with standard early-stage design tools in the Leading Edge Architecture
for Prototyping Systems (LEAPS) toolkit, including interfaces to the Rapid Ship Design
Environment (RSDE).
Finally, the Navy has the opportunity to implement this design framework, including the
P&E system flexibility metric, in its current design and acquisition program for its next-
generation large surface combatant, DDG(X).

